Article

Distributed Adaptive NN-Based Attitude Synchronous Tracking Control with Input Saturation
1
Research Center of Satellite Technology, Harbin Institute of Technology, Harbin 150001, China
2
Department of Control Science and Engineering, Harbin Institute of Technology, Harbin 150001, China
3
Department of Mechanical Science and Engineering, University of Illinois at Urbana-Champaign, Urbana, IL 61801, USA
*
Author to whom correspondence should be addressed.
Electronics 2022, 11(24), 4093; https://doi.org/10.3390/electronics11244093

Submission received: 28 October 2022 / Revised: 30 November 2022 / Accepted: 5 December 2022 / Published: 8 December 2022
(This article belongs to the Special Issue Design, Dynamics and Control of Robots)

Abstract

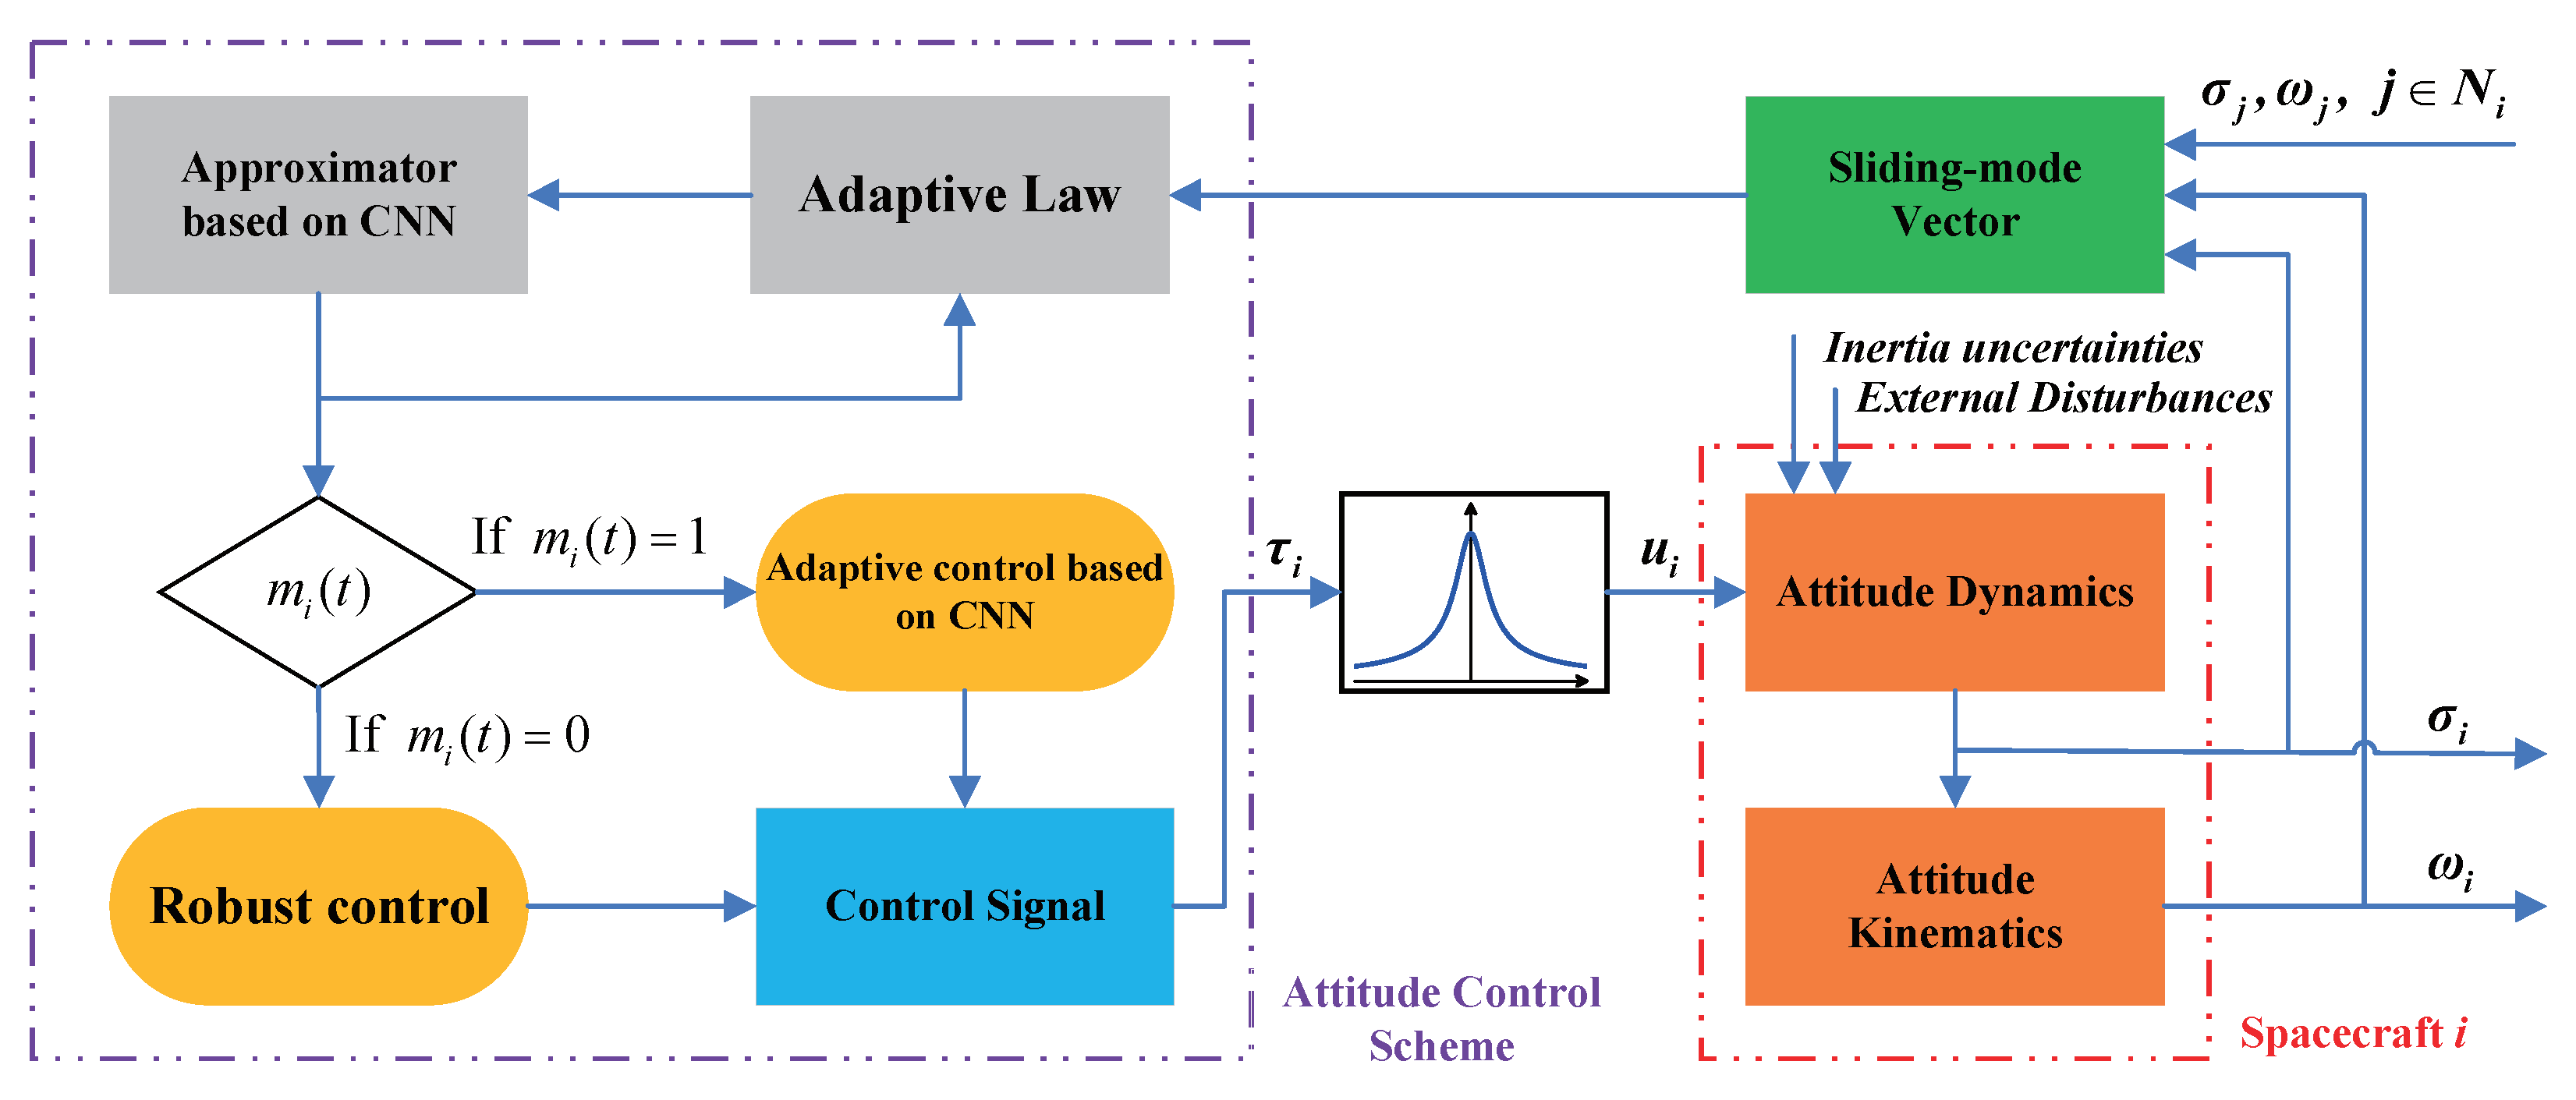
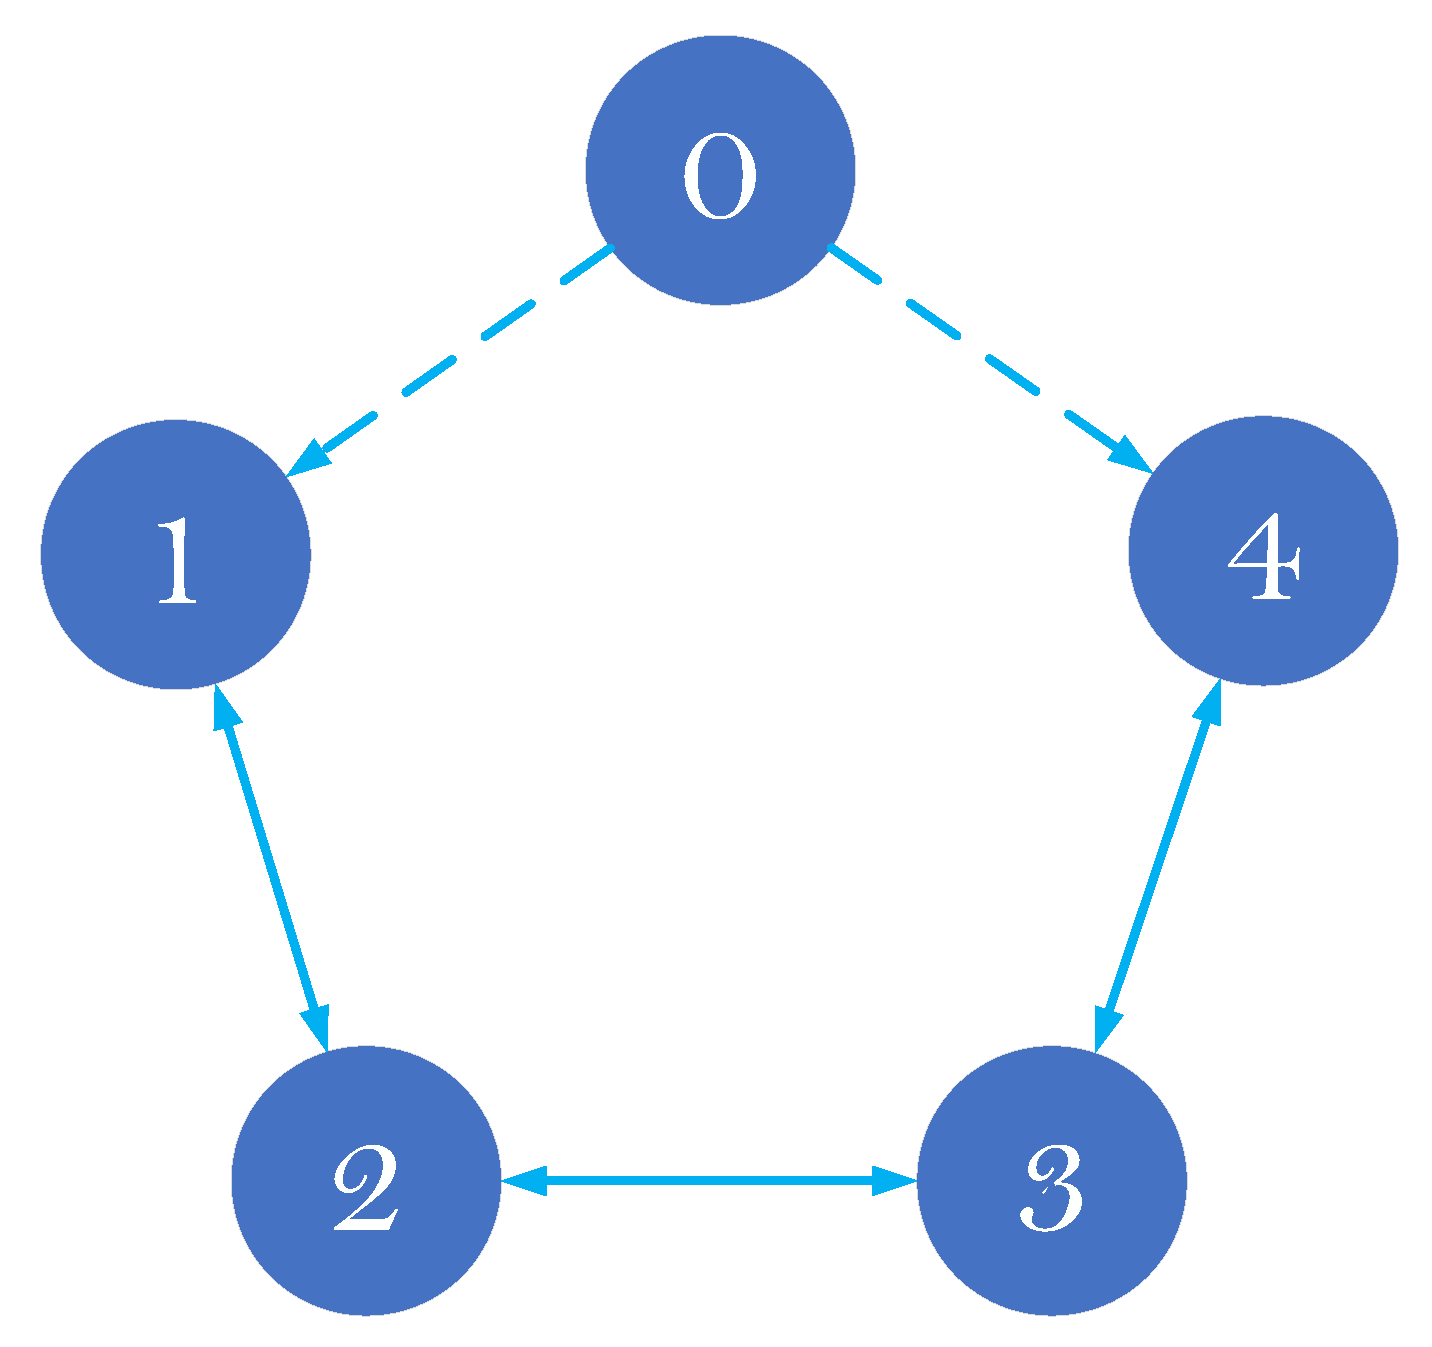
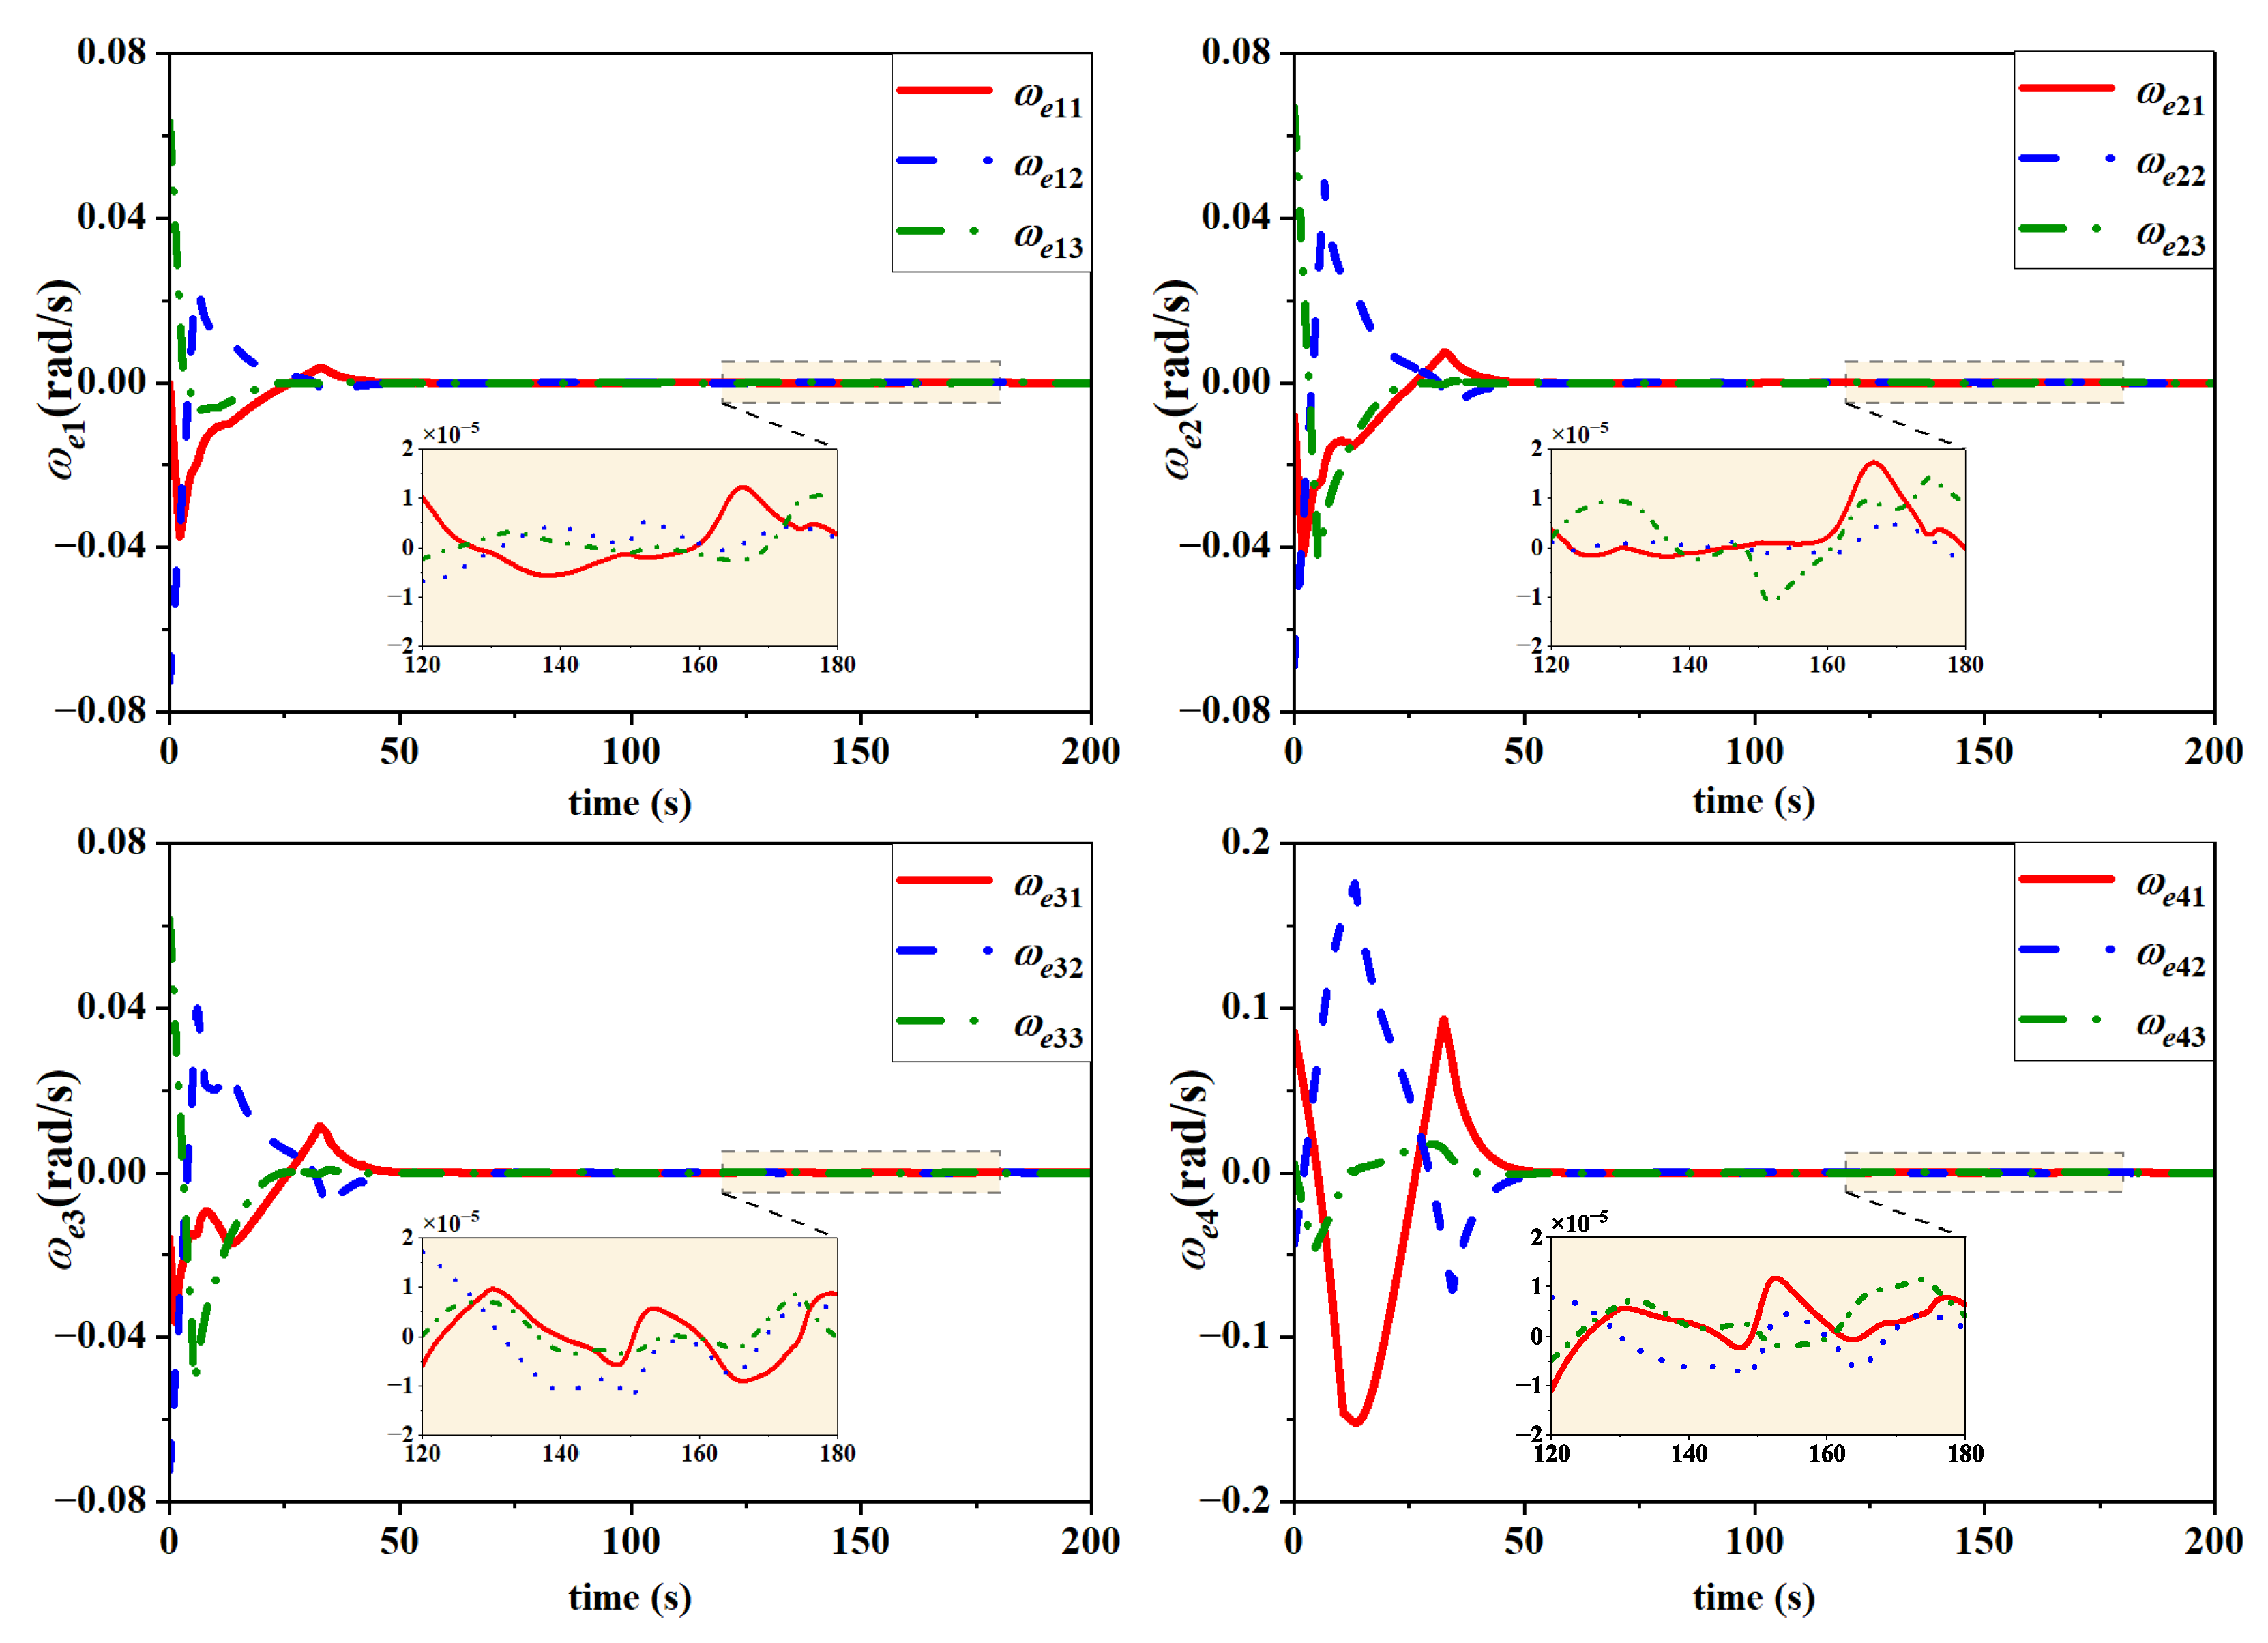
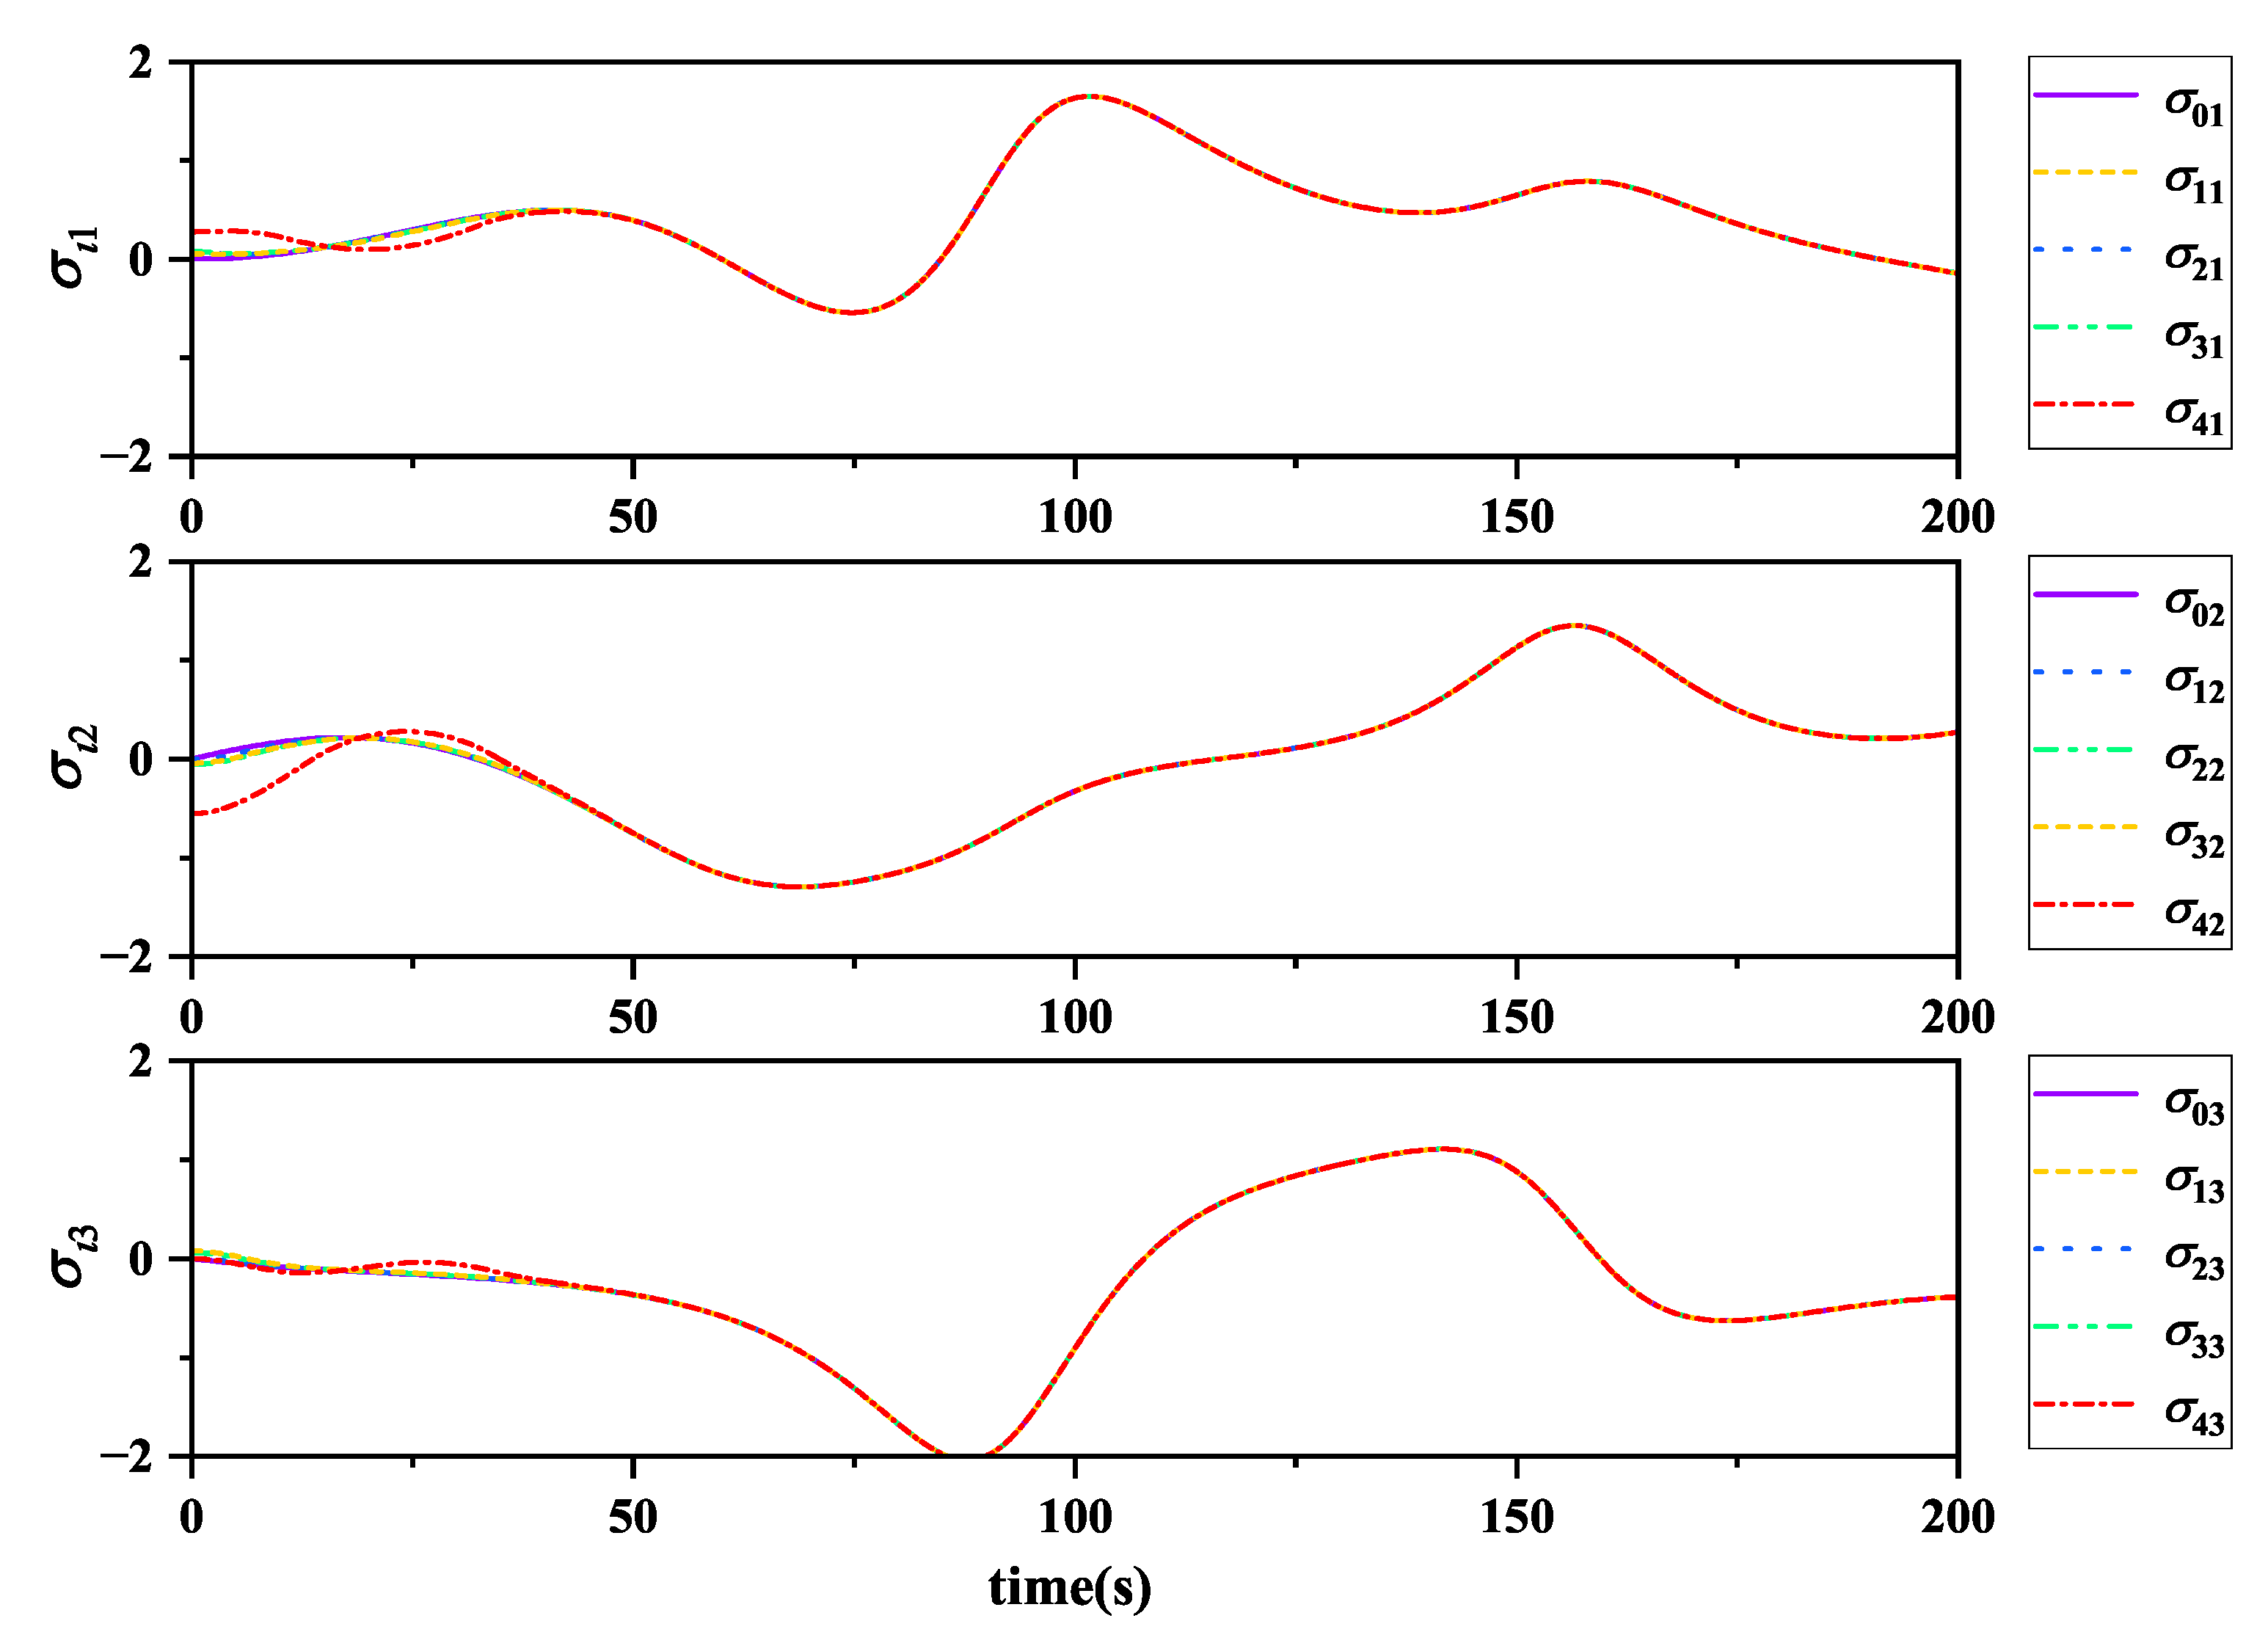
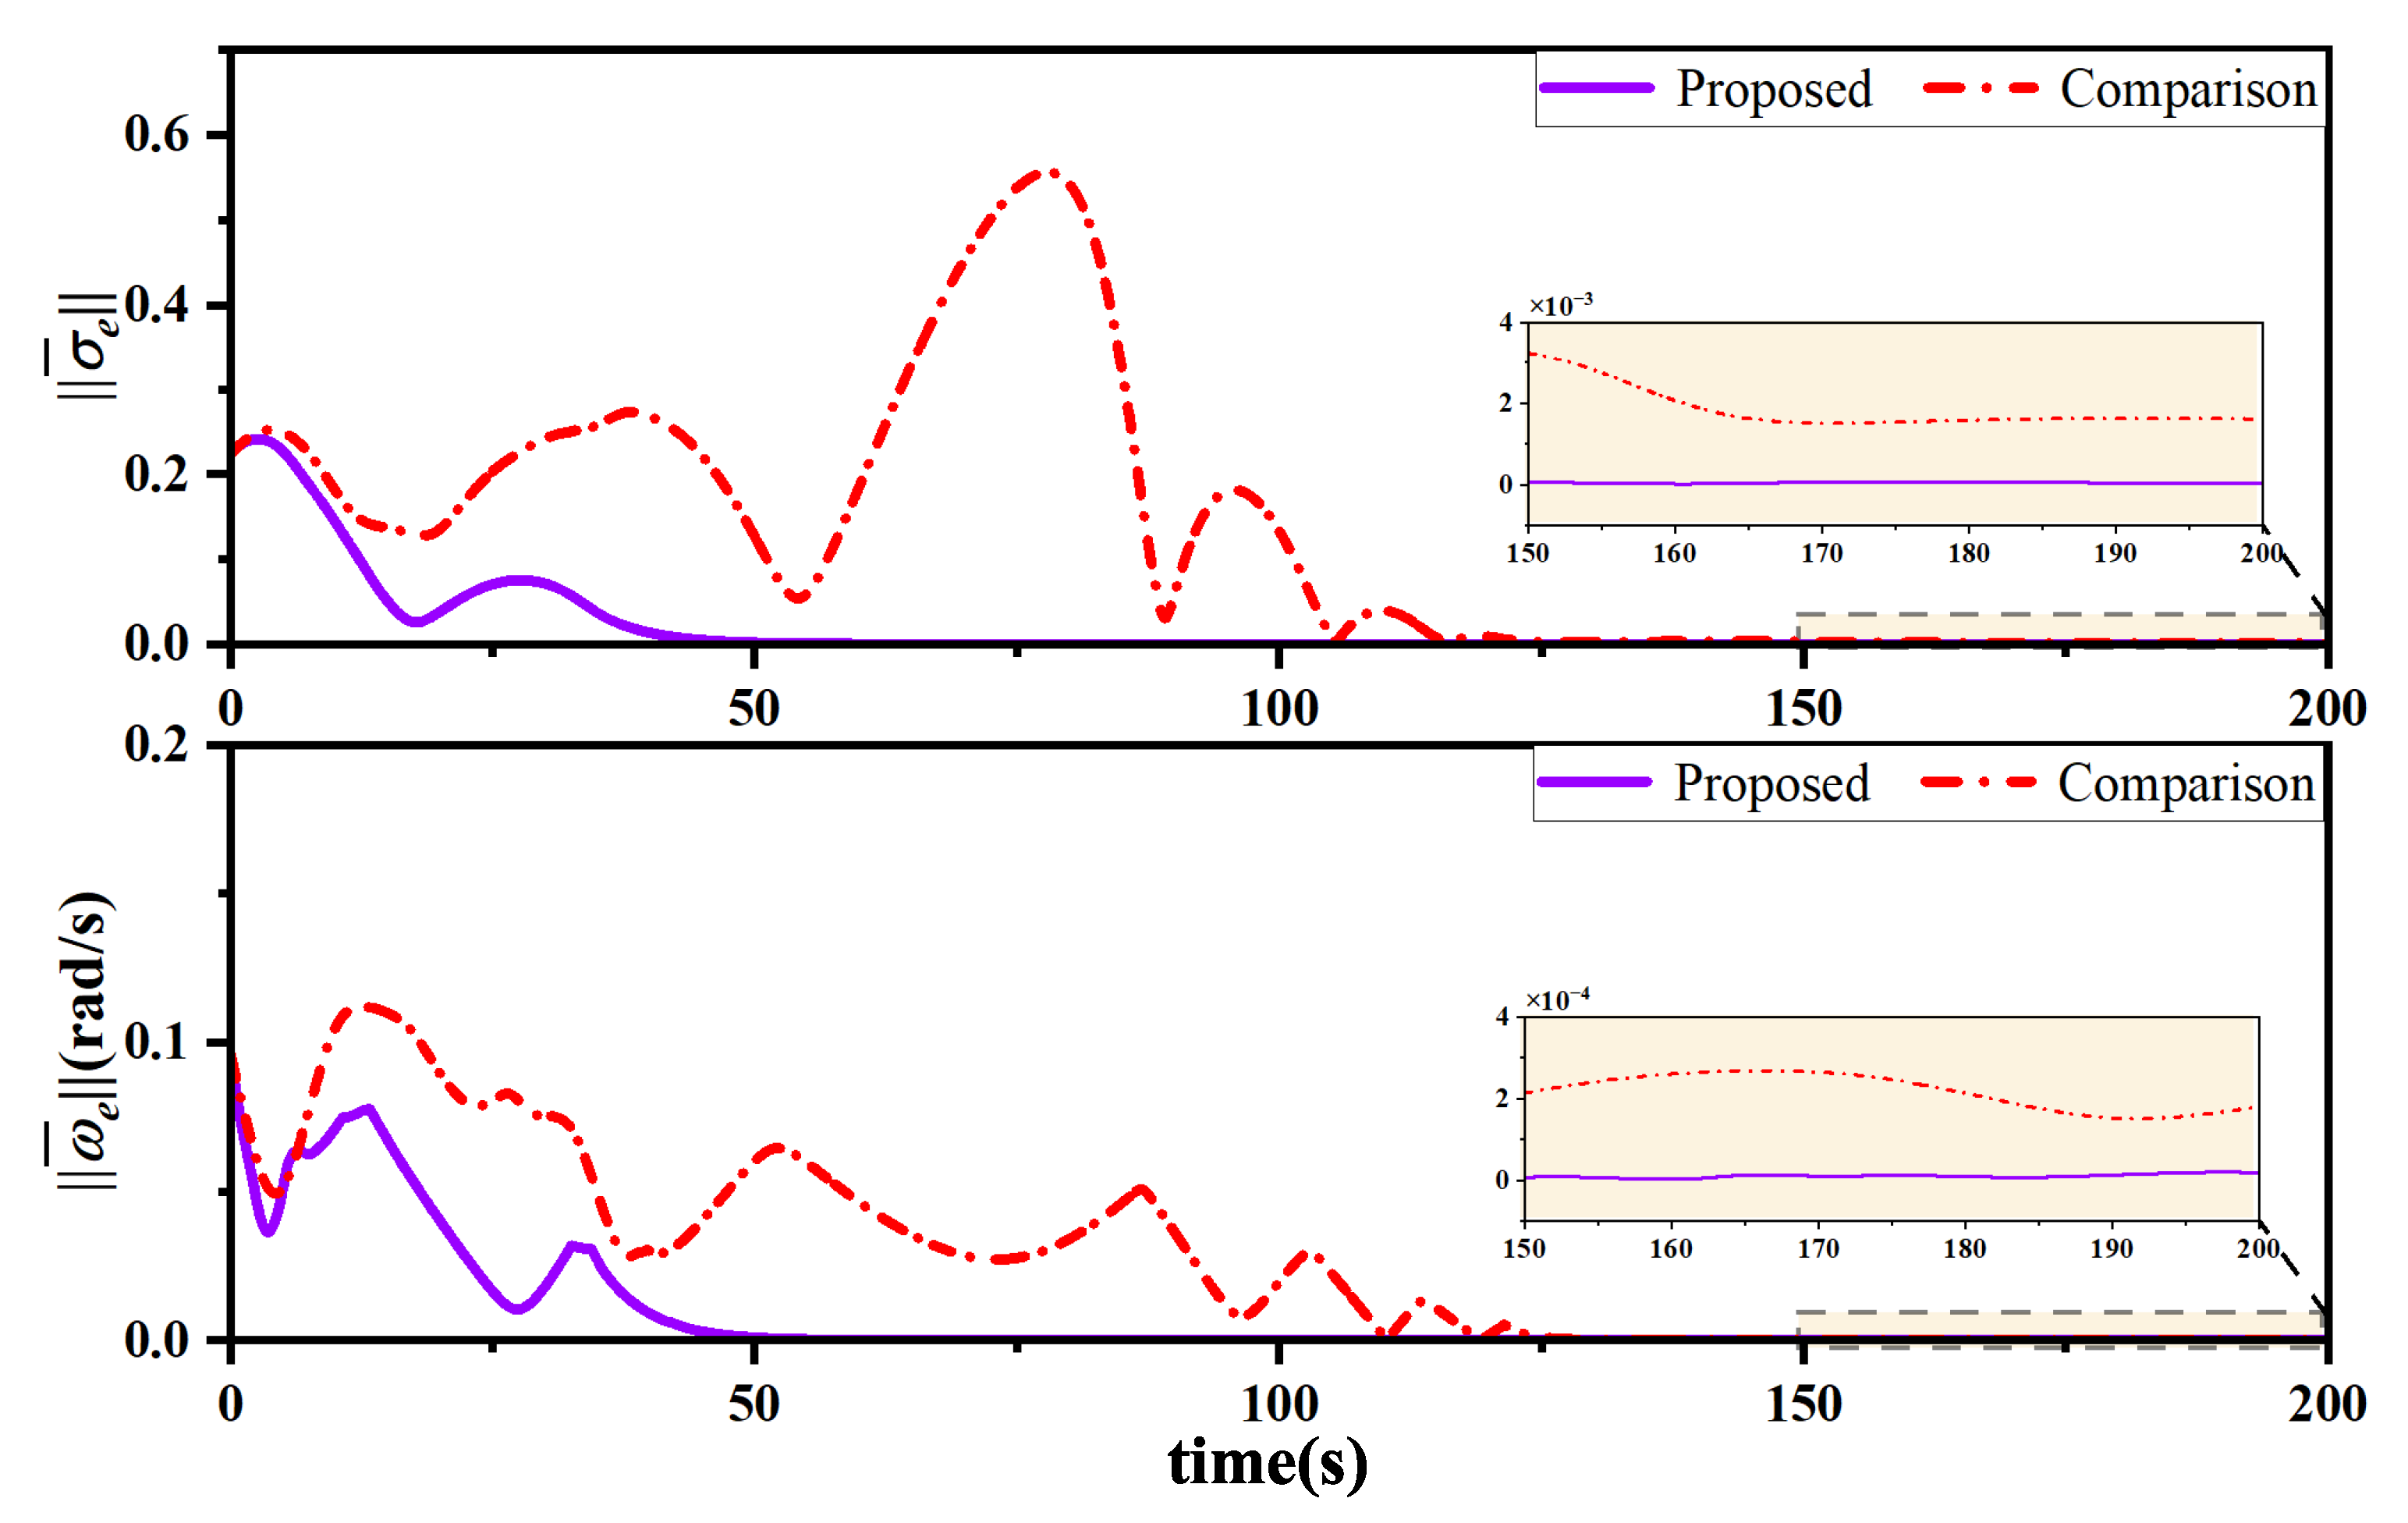
The attitude synchronization tracking problem for spacecraft formation flying is investigated in this paper based on sliding-mode control and a Chebyshev neural network (ChNN). A distributed attitude cooperative controller is designed for a group of spacecrafts to guarantee that each individual spacecraft will track the reference attitude of the virtual leader in the presence of external disturbances, system uncertainties and input saturation. An adaptive ChNN is introduced to approximate the system nonlinear uncertainties and bounded external disturbances online, and a switch function, which acts as a switching signal between the adaptive ChNN controller and the robust control law, is applied to limit the output of the ChNN approximator. Then, utilizing Nussbaum-type functions, an auxiliary control system is designed to counteract the nonlinearities caused by input saturation. Finally, a numerical simulation example is provided to illustrate the robustness and effectiveness of the proposed attitude control scheme.
Keywords: distributed attitude control; Chebyshev neural network; input saturation; sliding-mode control; Nussbaum-type function distributed attitude control; Chebyshev neural network; input saturation; sliding-mode control; Nussbaum-type function