


Abstract
This study presents a pulley-buoy-accelerated linear wave power generation system and verifies its feasibility and effectiveness through experimental research. Compared with traditional wave power generation systems that rely on three-stage energy conversion, the proposed system eliminates intermediate energy transfer and conversion links, enabling direct extraction of electrical energy from wave-induced motion. Additionally, by incorporating a pulley assembly, the system amplifies the buoy’s motion speed. This enhancement boosts the power output of the linear generator and improves the system’s overall wave energy conversion efficiency. Under laboratory conditions, a small-scale prototype of the system and a swing-type wave generator were constructed. Experimental tests were conducted to examine how three key factors influence the system’s power generation performance: the number of stator coils, wave conditions (wave height and wavelength), and buoy size. The results indicate that three measures can effectively improve both the wave energy conversion efficiency and power generation performance of the pulley-buoy-accelerated system: increasing the number of stator coils, increasing wave height and wavelength, and moderately enlarging the buoy size. These findings offer valuable insights for the practical application and efficient operation of wave power generation systems.
1. Introduction
Wave energy has attracted global widespread attention owing to its high energy density, abundant reserves, and extensive distribution [1,2]. In recent years, a number of successful wave energy technology applications have emerged across the world [3,4,5,6]. However, key issues remain unresolved in most wave energy converters: low power generation efficiency, insufficient structural reliability, and unstable system operation. These challenges have, to a certain degree, impeded the commercialization of wave energy generation technology [7,8,9].
Wave energy generation devices developed based on various mechanical principles have their own characteristics, but most of their power generation systems include three-level energy conversion links [10,11,12]. The first-level energy conversion system directly contacts the waves, captures wave energy, and converts it into mechanical energy or other energy of the carrier (referred to as first-level energy) [13]. The secondary energy conversion system converts the primary energy stored in different ways into mechanical energy forms that are easy to use by generators through mechanisms such as hydraulic motors, air turbines, or water turbines, and transfers them to the tertiary energy conversion system [14]. The three-level energy conversion system uses a generator for electromechanical conversion, ultimately achieving electrical energy output [15]. The collection and transmission of wave energy are important links in the process of wave energy generation [16,17]. Without considering the use of wave frequency boost conversion mechanisms, the more conversion stages between wave energy and electrical energy, the lower the efficiency of the power generation system. Therefore, reducing the number of energy conversion stages is one of the important means to improve the power generation efficiency of wave energy generation devices under existing low-frequency wave conditions.
In order to improve the power generation efficiency of wave energy generation devices, numerous new technologies have been applied to wave energy generation systems, and permanent magnet linear generator technology is one of the more effective new technologies [18,19,20]. When the internal permanent magnet rotor of a permanent magnet linear generator moves in a straight line, the direction of magnetic flux through the surrounding armature winding coils undergoes a reversal change, thus inducing current. Based on the working principle of linear generators and the characteristics of wave energy up and down movement, many scholars have started to apply this generator technology to wave energy generation. Ghaheri et al. [21] designed a novel linear transverse flux switching permanent magnet generator for direct-drive wave power generation systems. Dang et al. [22] designed a direct-drive wave power generation system using a variable stiffness mechanism. Several control strategies for direct-drive wave power generation systems were investigated including finite-time cascade-like tracking control [23], maximum power point tracking control [24], resonance control [25] and other novel control strategies [26,27]. However, among these devices, some necessitate underwater installation of the power generation system, while others demand rigid connection between the energy-harvesting buoy and the generator rotor. Consequently, the entire system suffers from several critical issues: inadequate waterproofing and corrosion resistance, insufficient structural reliability, weak resistance to wind and waves, and wave energy conversion efficiency that relies on specific wave conditions—namely, high wave heights and short wave periods.
Building on the aforementioned research, this study designs a pulley-buoy-accelerated linear wave energy generation system—distinct from traditional three-stage energy conversion wave energy systems—that only requires two stages of energy conversion. The design is based on a custom-developed linear power generation system. Compared with previous direct-drive devices, the innovation of the designed equipment lies in the principle of using a combination of pulleys to accelerate the movement of the buoy [28].
In this novel system, the oscillating buoy is directly connected to the rotor of the linear generator. This direct connection enables the extraction of electrical energy straight from wave-driven buoy motion, eliminating the need for intermediate energy transfer and conversion links. Additionally, the integration of a pulley assembly amplifies the buoy’s movement speed, which in turn multiplies the speed at which the rotor cuts magnetic induction lines within the linear generator. By the principle of electromagnetic induction, this speed enhancement boosts the power output of the linear generator, ultimately achieving the goal of improving the system’s wave energy conversion efficiency.
To verify the feasibility and effectiveness of this pulley-buoy-accelerated linear wave energy generation system, a small-scale prototype of the system and a swing-plate wave-generation system were constructed under laboratory conditions. By simulating various wave conditions, the effects of three key factors on the system’s power generation performance were investigated experimentally: stator coil count, wave conditions, and spherical buoy size.
2. Designed Wave Power Generation System
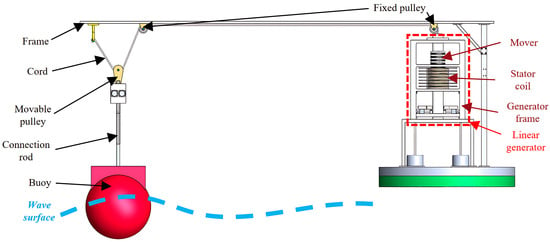
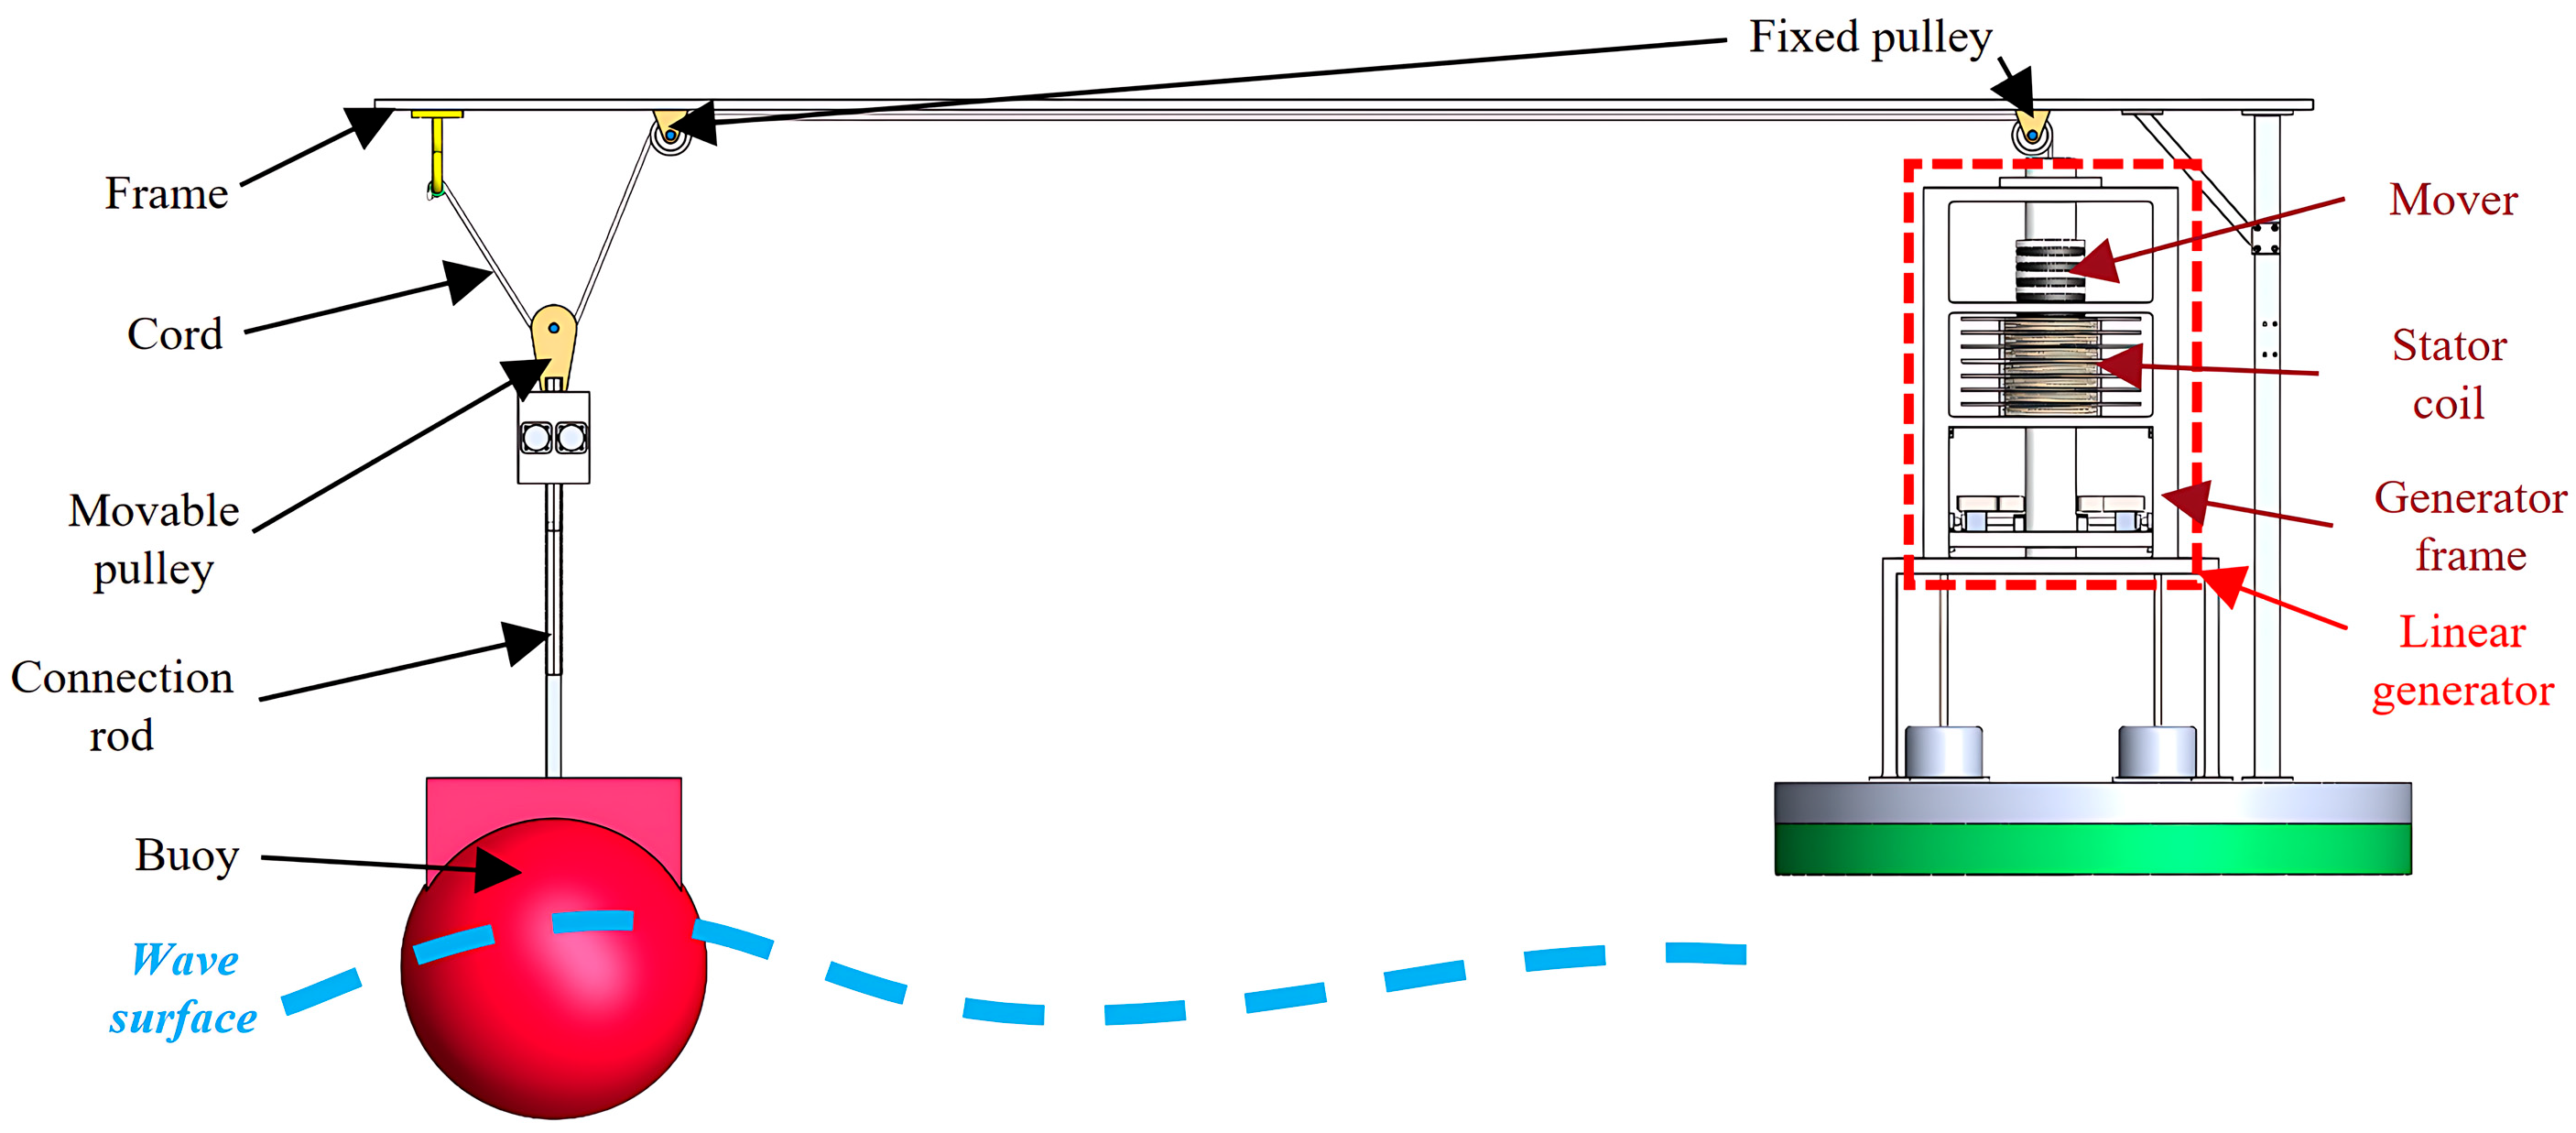
The pulley-buoy-accelerated linear wave power generation system is designed as shown in Figure 1. The proposed pulley-buoy-accelerated linear wave power generation system consists of a frame, a buoy, a connection rod, a movable pulley, a cord, two fixed pulleys, and a linear generator. The linear generator includes a generator frame, a mover, and a stator coil. The linear generator is mounted on the frame and the stator coil is fixed on the generator frame. The mover is connected with the cord and can move through the stator coil linearly. The buoy is connected with the connection rod and the connection rod is fixed on the movable pulley. The movable pulley, cord, and two fixed pulleys form a pulley assembly. The movement of the buoy is transferred to the mover through the pulley assembly. According to the principle of movable pulleys [29], the speed of the mover is twice that of the buoy.
Figure 1.
Schematic diagram of the proposed pulley-buoy-accelerated linear wave power generation system.
The working principle of the designed pulley-buoy-accelerated linear wave power generation system is as follows. First, the undulating wave surface drives the buoy to move up and down. Then, the movement of the buoy makes the mover move in a straight line at a rate several times that of the buoy through the pulley assembly, and the mover cuts the magnetic induction line of the stator coil to generate electricity. In order to reduce the blocking effect, the shape of the buoy is designed to be spherical. The sphere itself is a relatively smooth geometric shape. Compared with some angular or irregular buoy designs, the spherical buoy is relatively less subject to water flow resistance when moving in the water flow, and the water flow can flow over the buoy surface more smoothly. For example, under the same volume, a square buoy may cause greater obstruction due to the larger contact surface between the flat part and the water flow, while a spherical buoy can make the water flow more naturally, which may reduce the blocking effect of the buoy’s own shape on the surrounding water flow to a certain extent, reduce the degree of change in the water flow and wave shape around the device, and indirectly affect the blocking effect of the entire device.
The critical dimensions of the device are as follows: the length, width, and height of the device are 4750 mm, 1036 mm, and 1892 mm. Fabricated from stainless steel, the device incorporates sealing structures at its movement joints. Designed for coastal deployment as a shore-based wave energy converter, it is intended to harness wave energy for electricity generation.
Essential theoretical foundations and mathematical models of the proposed pulley-buoy-accelerated linear wave power generation system are shown in Appendix A.
3. Swing-Plate Wave-Making System
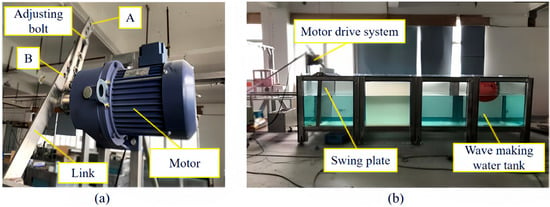
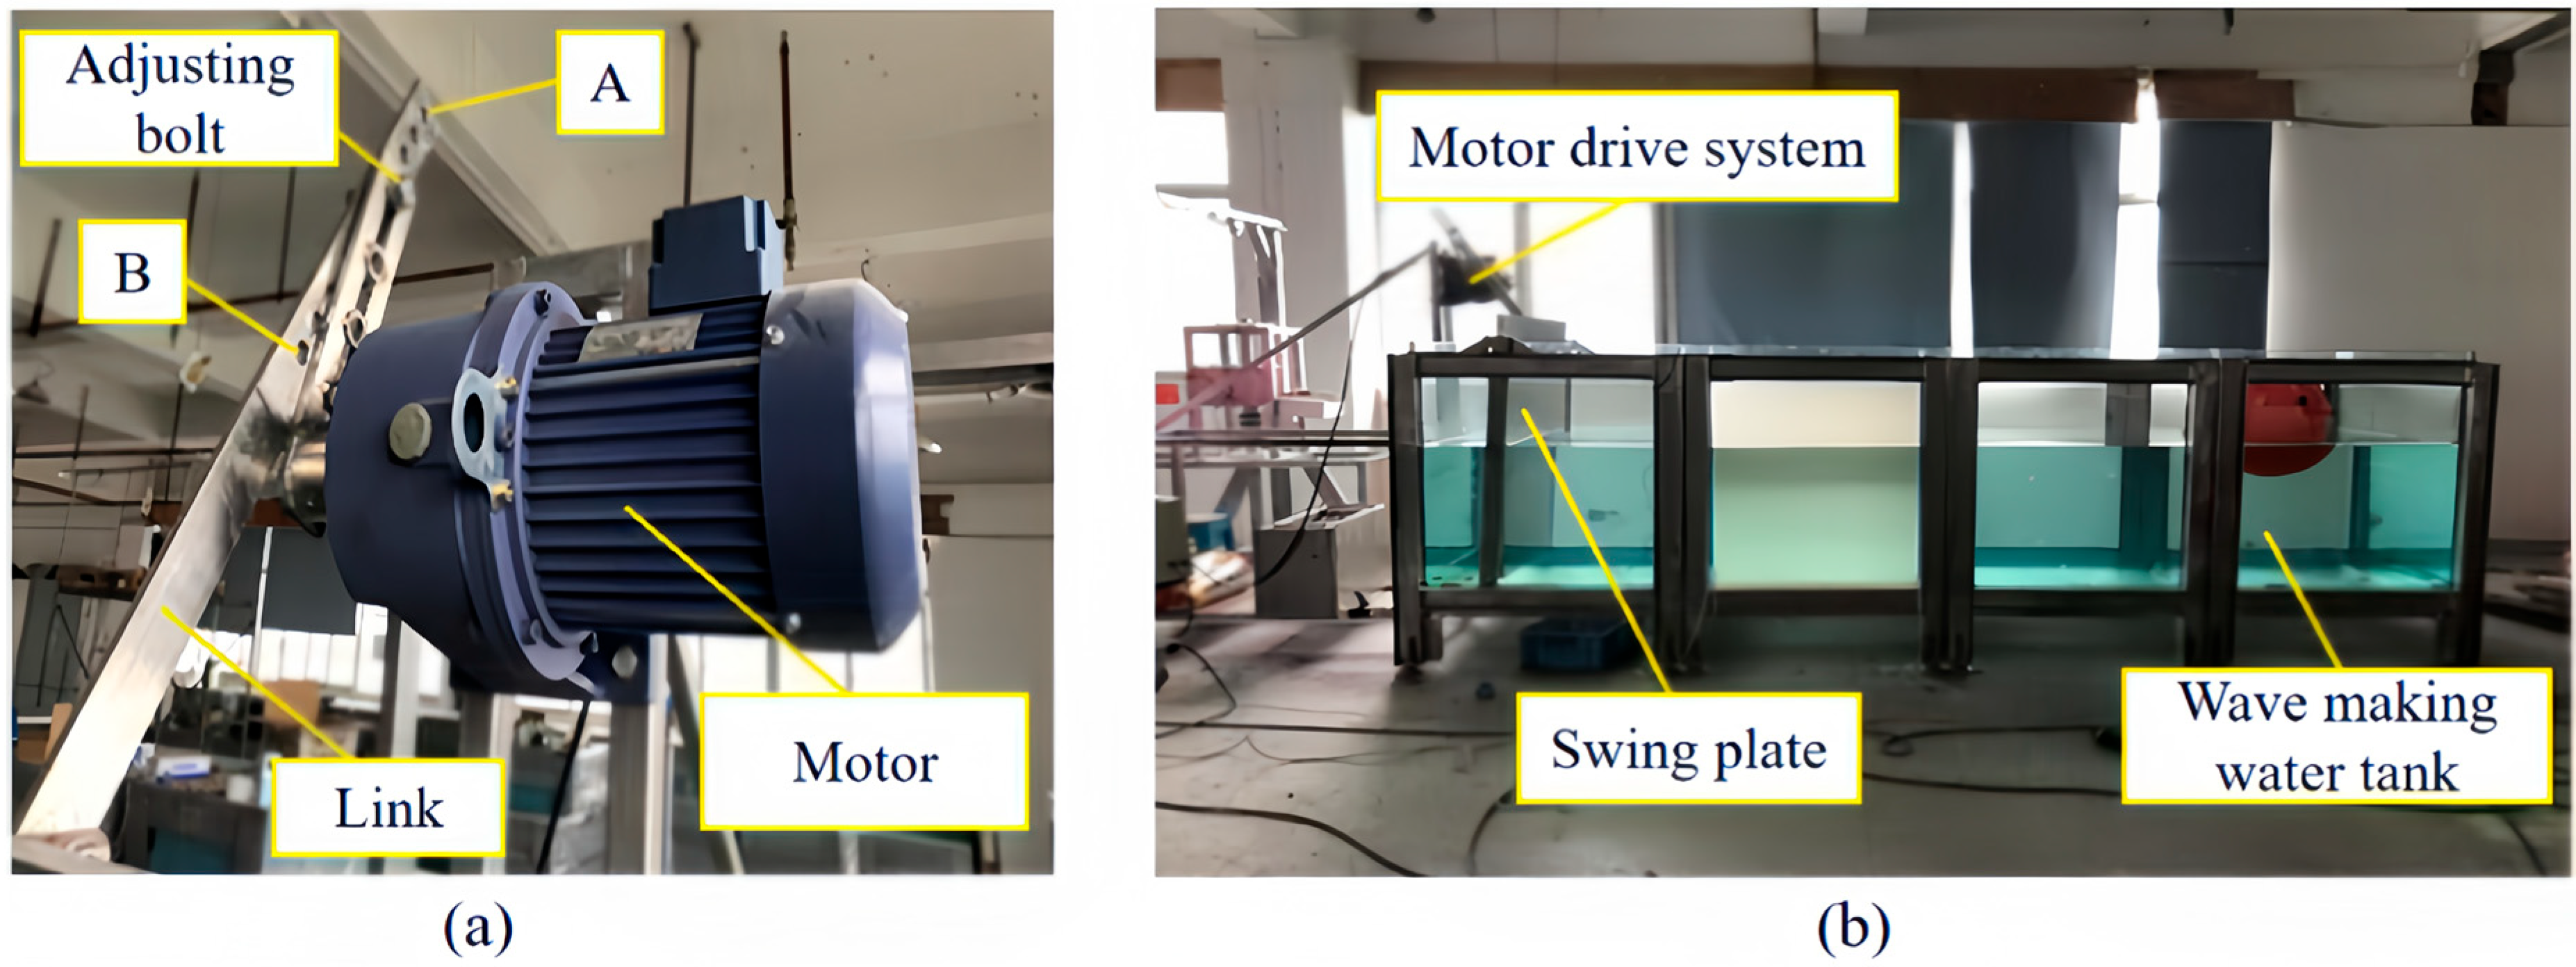
To verify the effectiveness of the pulley-buoy-accelerated linear wave energy conversion system, a swing-plate wave-generating system was created under laboratory conditions. The system’s energy conversion performance was then evaluated by simulating wave movements. As depicted in Figure 2, the swing-plate wave-generating system primarily consists of three components: a motor drive control system, a motor drive system, and a wave simulation system. As shown in Figure 2a, the motor drive system mainly includes a crank-connecting rod mechanism and an asynchronous alternating current (AC) motor. Meanwhile, as illustrated in Figure 2b, the wave simulation system primarily consists of a wave-generating tank and a swing plate.
Figure 2.
Swing-plate wave-making system: (a) motor drive system; (b) wave simulation system.
The basic parameters of the wave-making tank are set to 4 m × 1.2 m × 1.2 m, and those of the swing plate are 1.5 m × 1.15 m × 0.03 m. Mounted along the long side of the tank, the swing plate is positioned 0.3 m away from the tank edge. Its lower end is hinged to the tank bottom, enabling reciprocating swing around a fixed bottom axis; when swinging backward, the plate is perpendicular to the stationary water surface. A hinge point is arranged on the upper part of the swing plate, which is connected to the crank-connecting rod mechanism. As illustrated in Figure 2a, the swing-plate wave-making system creates simulated waves with varying heights and wavelengths under the drive of the motor system. When the connecting rod and crankshaft are connected at hole A via adjusting bolts, the effective length of the connecting rod increases, leading to a larger swing angle of the plate and thus generating waves with greater wavelengths and heights. In contrast, when the connection is made at hole B using the same adjusting bolts, the swing plate exhibits a smaller swing angle, resulting in waves with smaller wavelengths and heights. The motor drive control system incorporates a frequency converter: by adjusting the motor’s input frequency and altering its rotational speed, the motion cycle of the swing plate can be modified to create simulated waves of different periods. The wave conditions achievable by the swing-plate wave-making system are as follows: wave amplitude ranges from 0.08 to 0.18 m, and wave period ranges from 0.8 to 1.6 s.
4. Experimental Methods
4.1. Experimental Setup
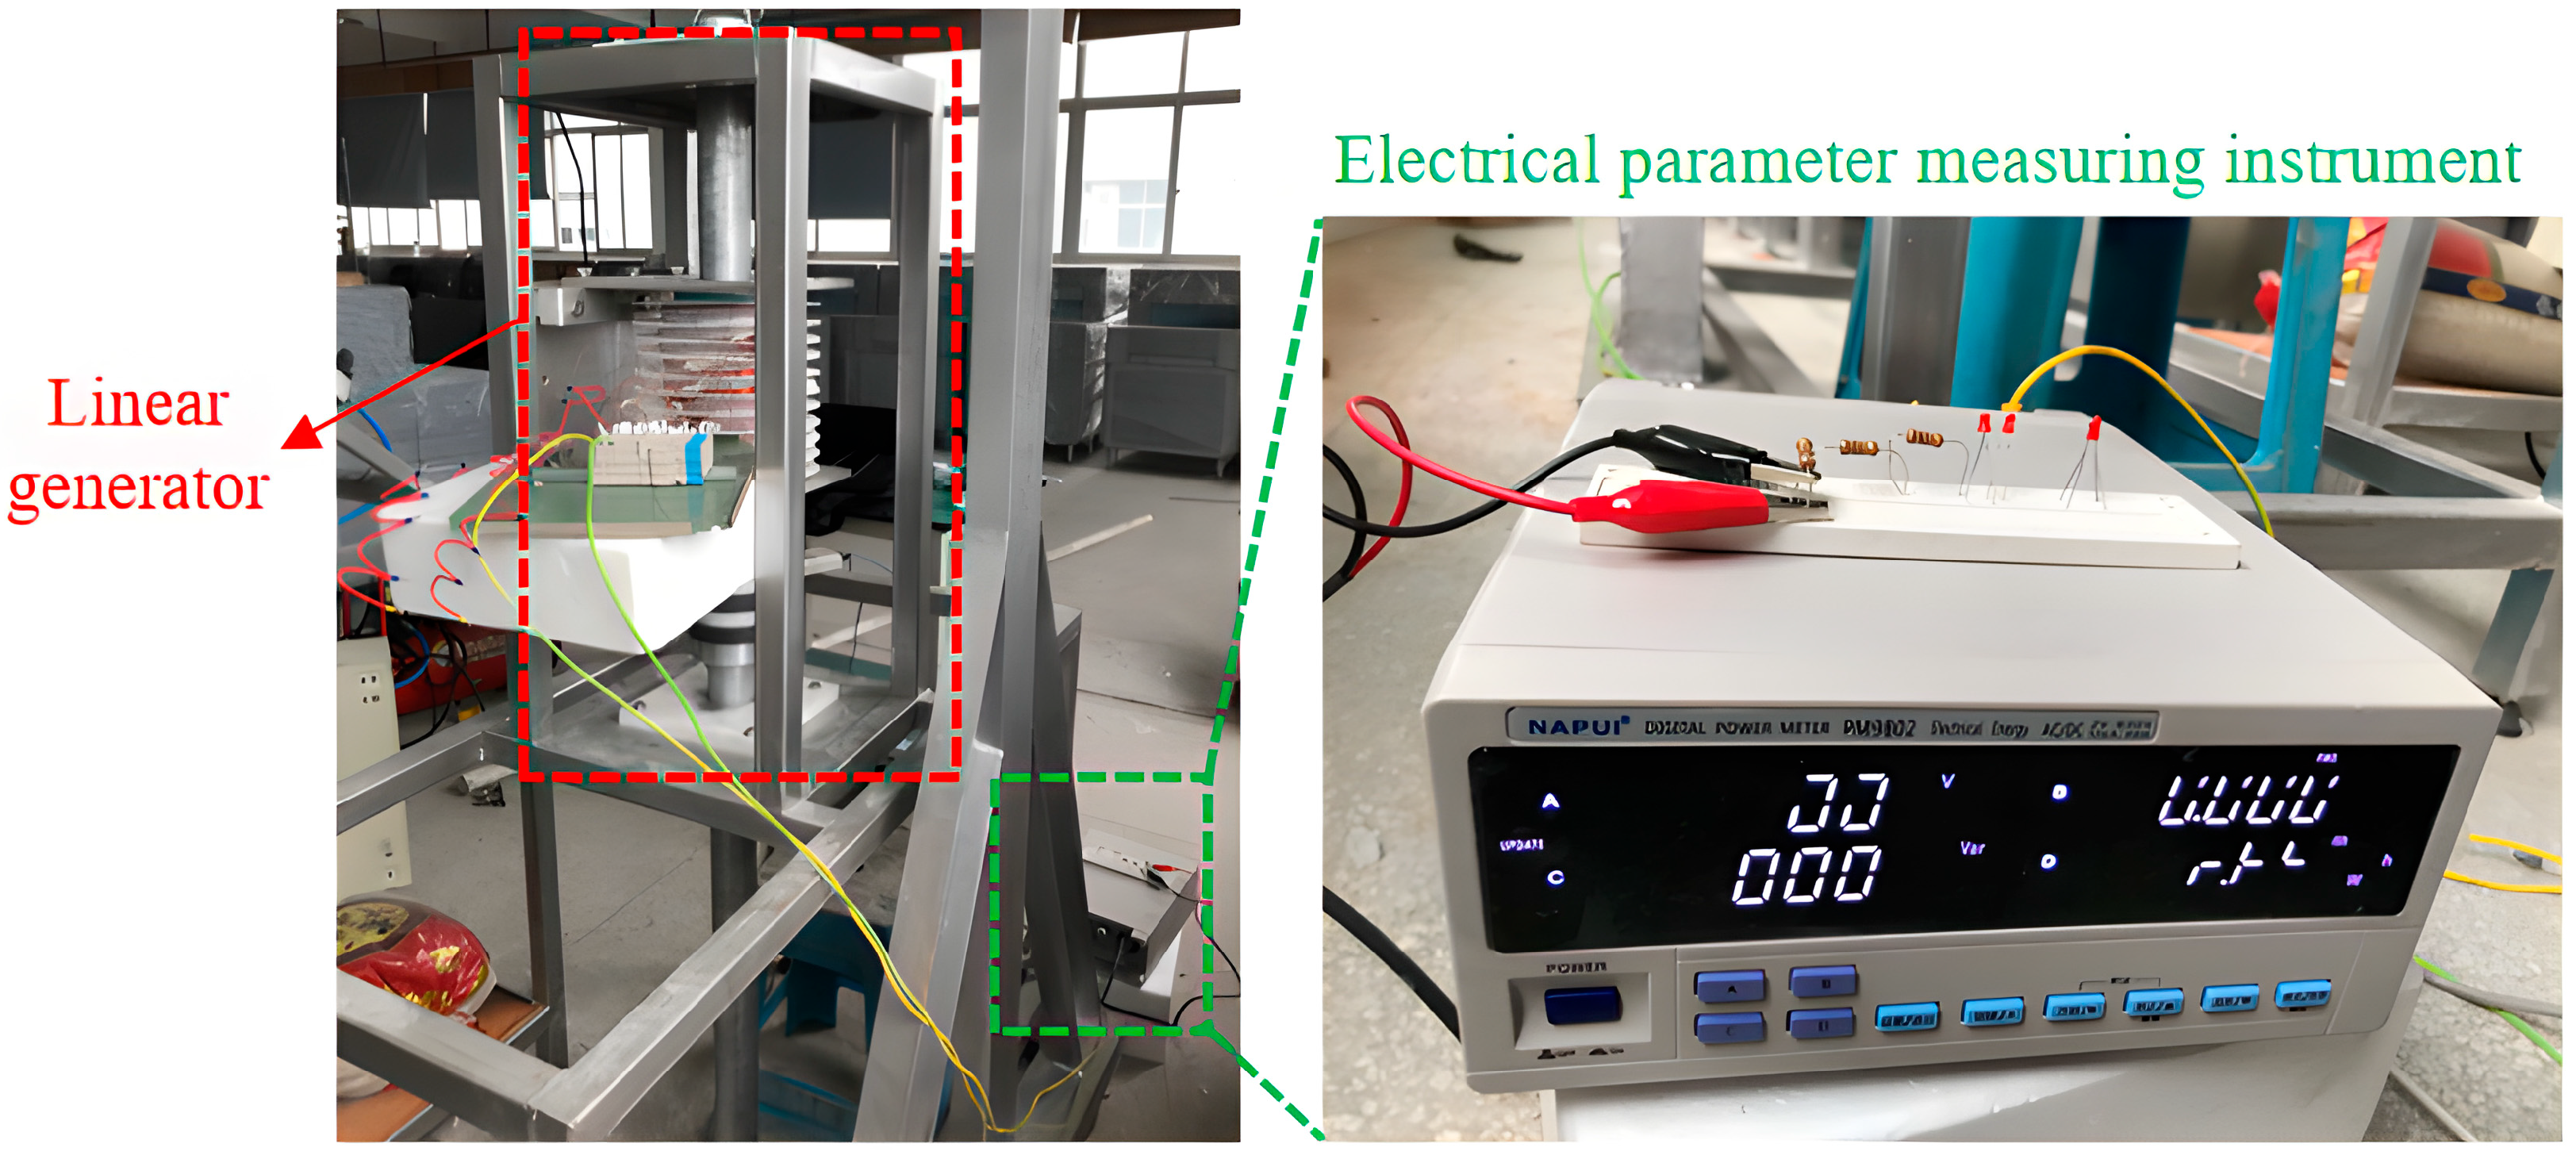
The positions and connections of the components during the test are shown in Figure 1 and Figure 3. The gantry frame is moved above the wave-making tank, and the buoy is connected to the movable pulley and placed in the tank. The main performance parameters such as voltage and current during the test are measured by a digital electrical parameter measuring instrument. The PM9802 AC and direct current (DC) parameter measuring instrument (NAPUI Co., Dongguan, China) is used as the digital electrical parameter measuring instrument. The measurement accuracy and measurement uncertainty of the voltage are 0.01 V and 1 mV, respectively. The measurement accuracy and measurement uncertainty of the current are 1 mA and 0.1 mA, respectively. The measurement accuracy and measurement uncertainty of the power are 0.01 mW and 0.001 mW, respectively. Power measurement is carried out using a 9k resistor as the electrical load. Both the measurement accuracy and measurement uncertainty belong to the high precision range. In order to ensure the credibility of the final test results, the error propagation root mean square method is used to analyze the uncertainty of the test results of the test system. The uncertainty analysis of the test measurement is shown in Table 1. The analysis results show that the uncertainty of wave energy extraction power and energy capture width ratio is less than 1.0%. Therefore, the test results have a high degree of credibility.
Figure 3.
Measurement of the output current and voltage of WEC using electric parameter measuring instrument.
Table 1.
Uncertainty analysis of test measurements.
For wave conditions setting, water depth is 1 m. The wave heights and wave periods at the buoy location are set as listed in Table 2, named as Condition 1 (wave amplitude = 0.15 m, wave period = 1 s), Condition 2 (wave amplitude = 0.25 m, wave period = 1 s), and Condition 3 (wave amplitude = 0.15 m, wave period = 1.5 s).
Table 2.
Three wave conditions used in the experiment.
The wave height measuring instrument is a capacitive wave height meter, CBG03 (Chengdu University of Science and Technology Shengying Company, Chengdu, China), with a wave height measurement accuracy of 0.3%. The wave period is not measured separately, but is calculated from the time series data of wave height. The wave height meter is installed directly to ensure measurement accuracy, avoiding turbulent areas near the wave generator and reflection areas at the edge of the water tank, with a distance of ≥600 mm from the water tank wall to reduce reflection interference.
4.2. Test on Effects of Number of Stator Coils
This study examined the effect of varying stator coil counts on the electrical output power of a linear power generation system under constant wave conditions. The experimental procedures are detailed as follows:
STEP1: Fix the number of annular magnets affixed to the aluminum main shaft of the linear power generation system at 4, and set the number of stator coils to 1. Connect the generator coil to a digital electrical parameter measuring instrument, as illustrated in Figure 3.
STEP2: To maintain constant wave conditions: adjust the output frequency of the inverter in the motor drive control system to a fixed value, thereby maintaining the drive motor speed and ensuring a consistent period for the simulated waves; set the crank length of the connecting rod mechanism to a constant parameter, which stabilizes the swing angle of the swing plate and consequently keeps the wave height and wavelength of the simulated waves unchanged.
STEP3: Position a spherical buoy (diameter: 650 mm) in the wave-making tank, switch on the drive motor to initiate operation, and the wave-making swing plate and buoy in the tank will undergo periodic motion. After the system reaches a steady state, measure and record the current and voltage of the linear power generation system, followed by calculating the electrical output power.
STEP4: With the number of annular magnets on the mover remaining unchanged, gradually increase the number of stator coils to 2, 3, 4, 5, and 6 sequentially. Repeat the aforementioned test procedures to measure the electrical output power of the same buoy system under the fixed wave conditions, aiming to explore the influence of varying coil numbers on the system’s power generation performance.
4.3. Test on Effects of Wave Conditions and Buoy Sizes
To investigate the effects of different wave conditions and buoy sizes on the pulley-buoy-accelerated wave energy power generation system, three distinct wave conditions were simulated during the test. Two spherical buoys of varying sizes were also fabricated and selected, and comparative tests were conducted to study the system’s power generation performance. The test procedures are as follows:
Set the number of annular magnets in the linear power generation system to 5 and the number of stator coils to 8.
- (1)
- Position the adjusting bolt in the crank-connecting rod mechanism at the B-hole position, then adjust the inverter to set the drive motor speed to 150 rpm. The wave condition generated at this point is recorded as the first wave condition.
- (2)
- Reposition the adjusting bolt to the A-hole position while keeping the drive motor speed at 150 rpm. The corresponding wave condition is recorded as the second wave condition.
- (3)
- Maintain the adjusting bolt at the A-hole position, adjust the inverter to reduce the drive motor speed to 120 rpm. The resulting wave condition is recorded as the third wave condition.
- (4)
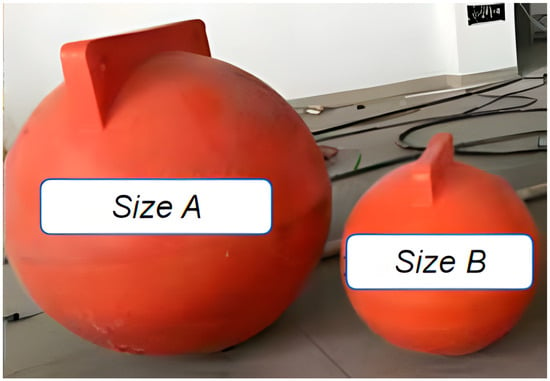
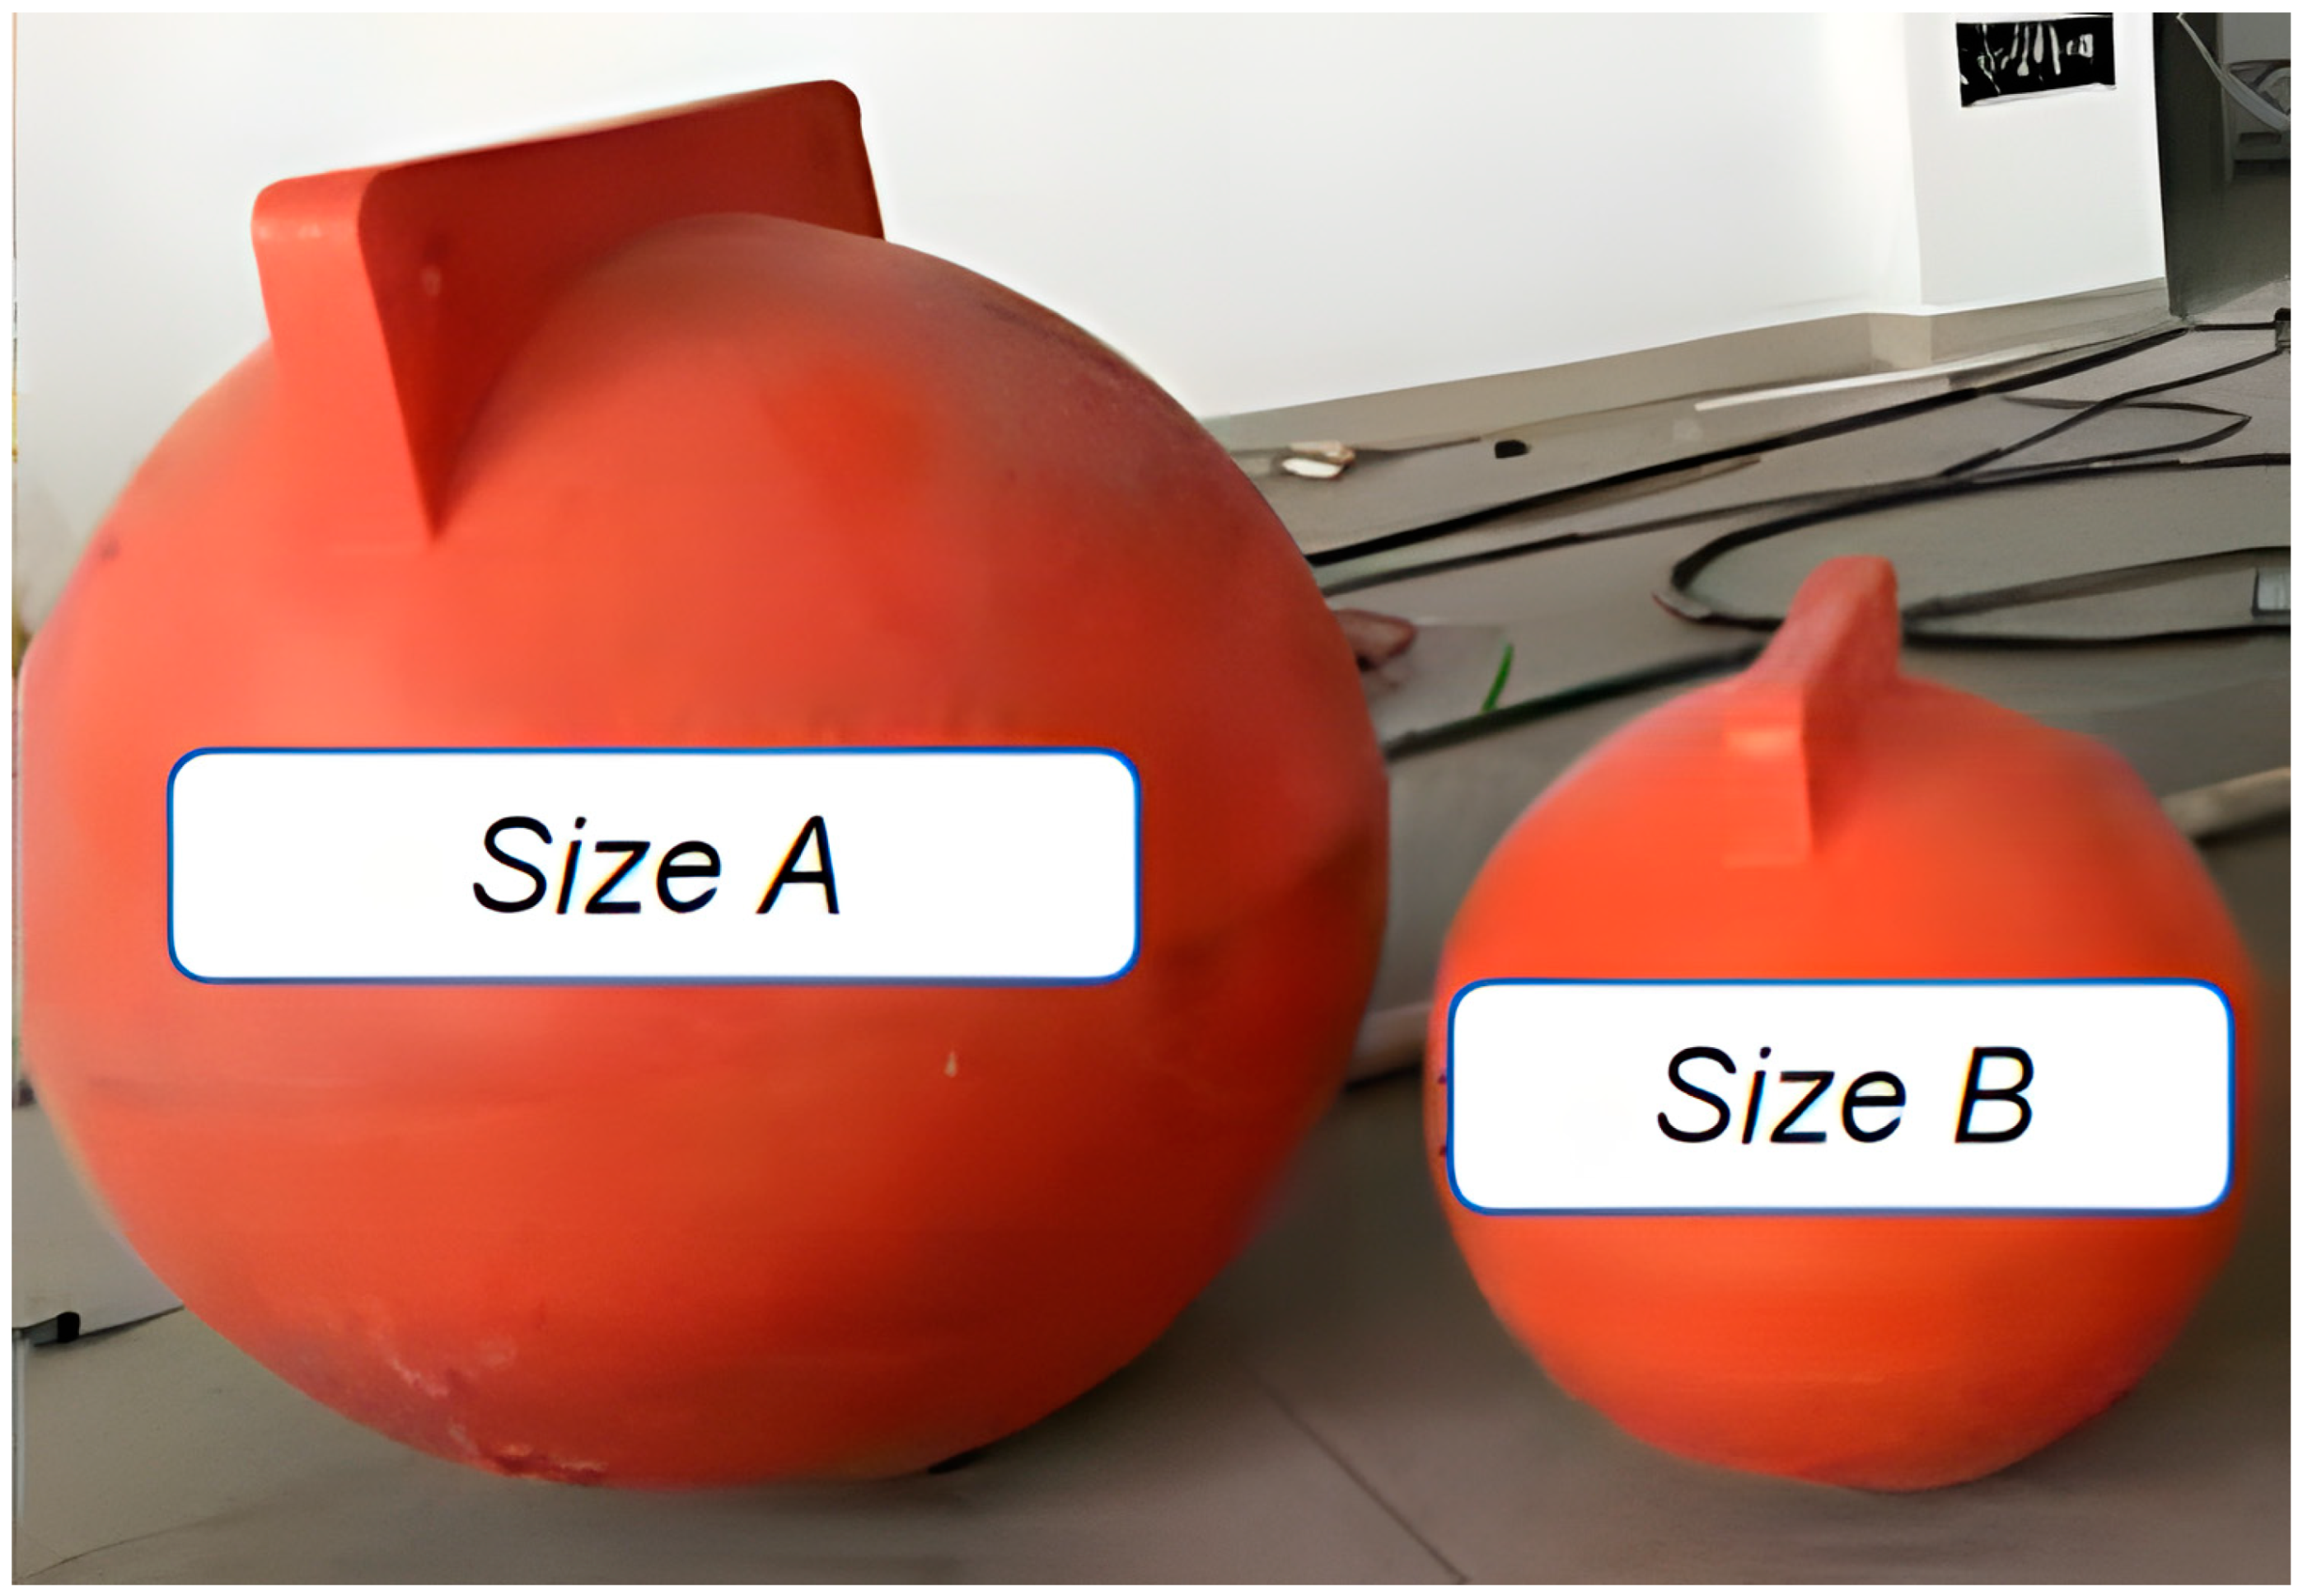
- Place two spherical buoys—with diameters of 500 mm (designated as Size A) and 310 mm (designated as Size B), photos shown in Figure 4, and characteristic data presented in Table 3—into the wave-making tank. Conduct controlled tests for each buoy under the three wave conditions sequentially. After the system stabilizes, measure and record the current and voltage of the linear power generation system, then calculate the power output.Figure 4. Two spherical buoys used in the experiment.Table 3. Main characteristics data of the buoy.
- (5)
- Compare the system’s power generation performance across different test conditions to investigate how wave conditions and buoy size affect the system’s power output.
5. Results and Discussion
5.1. Effects of Number of Stator Coils on Power Generation
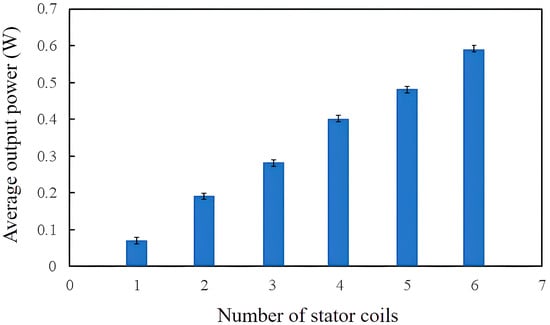
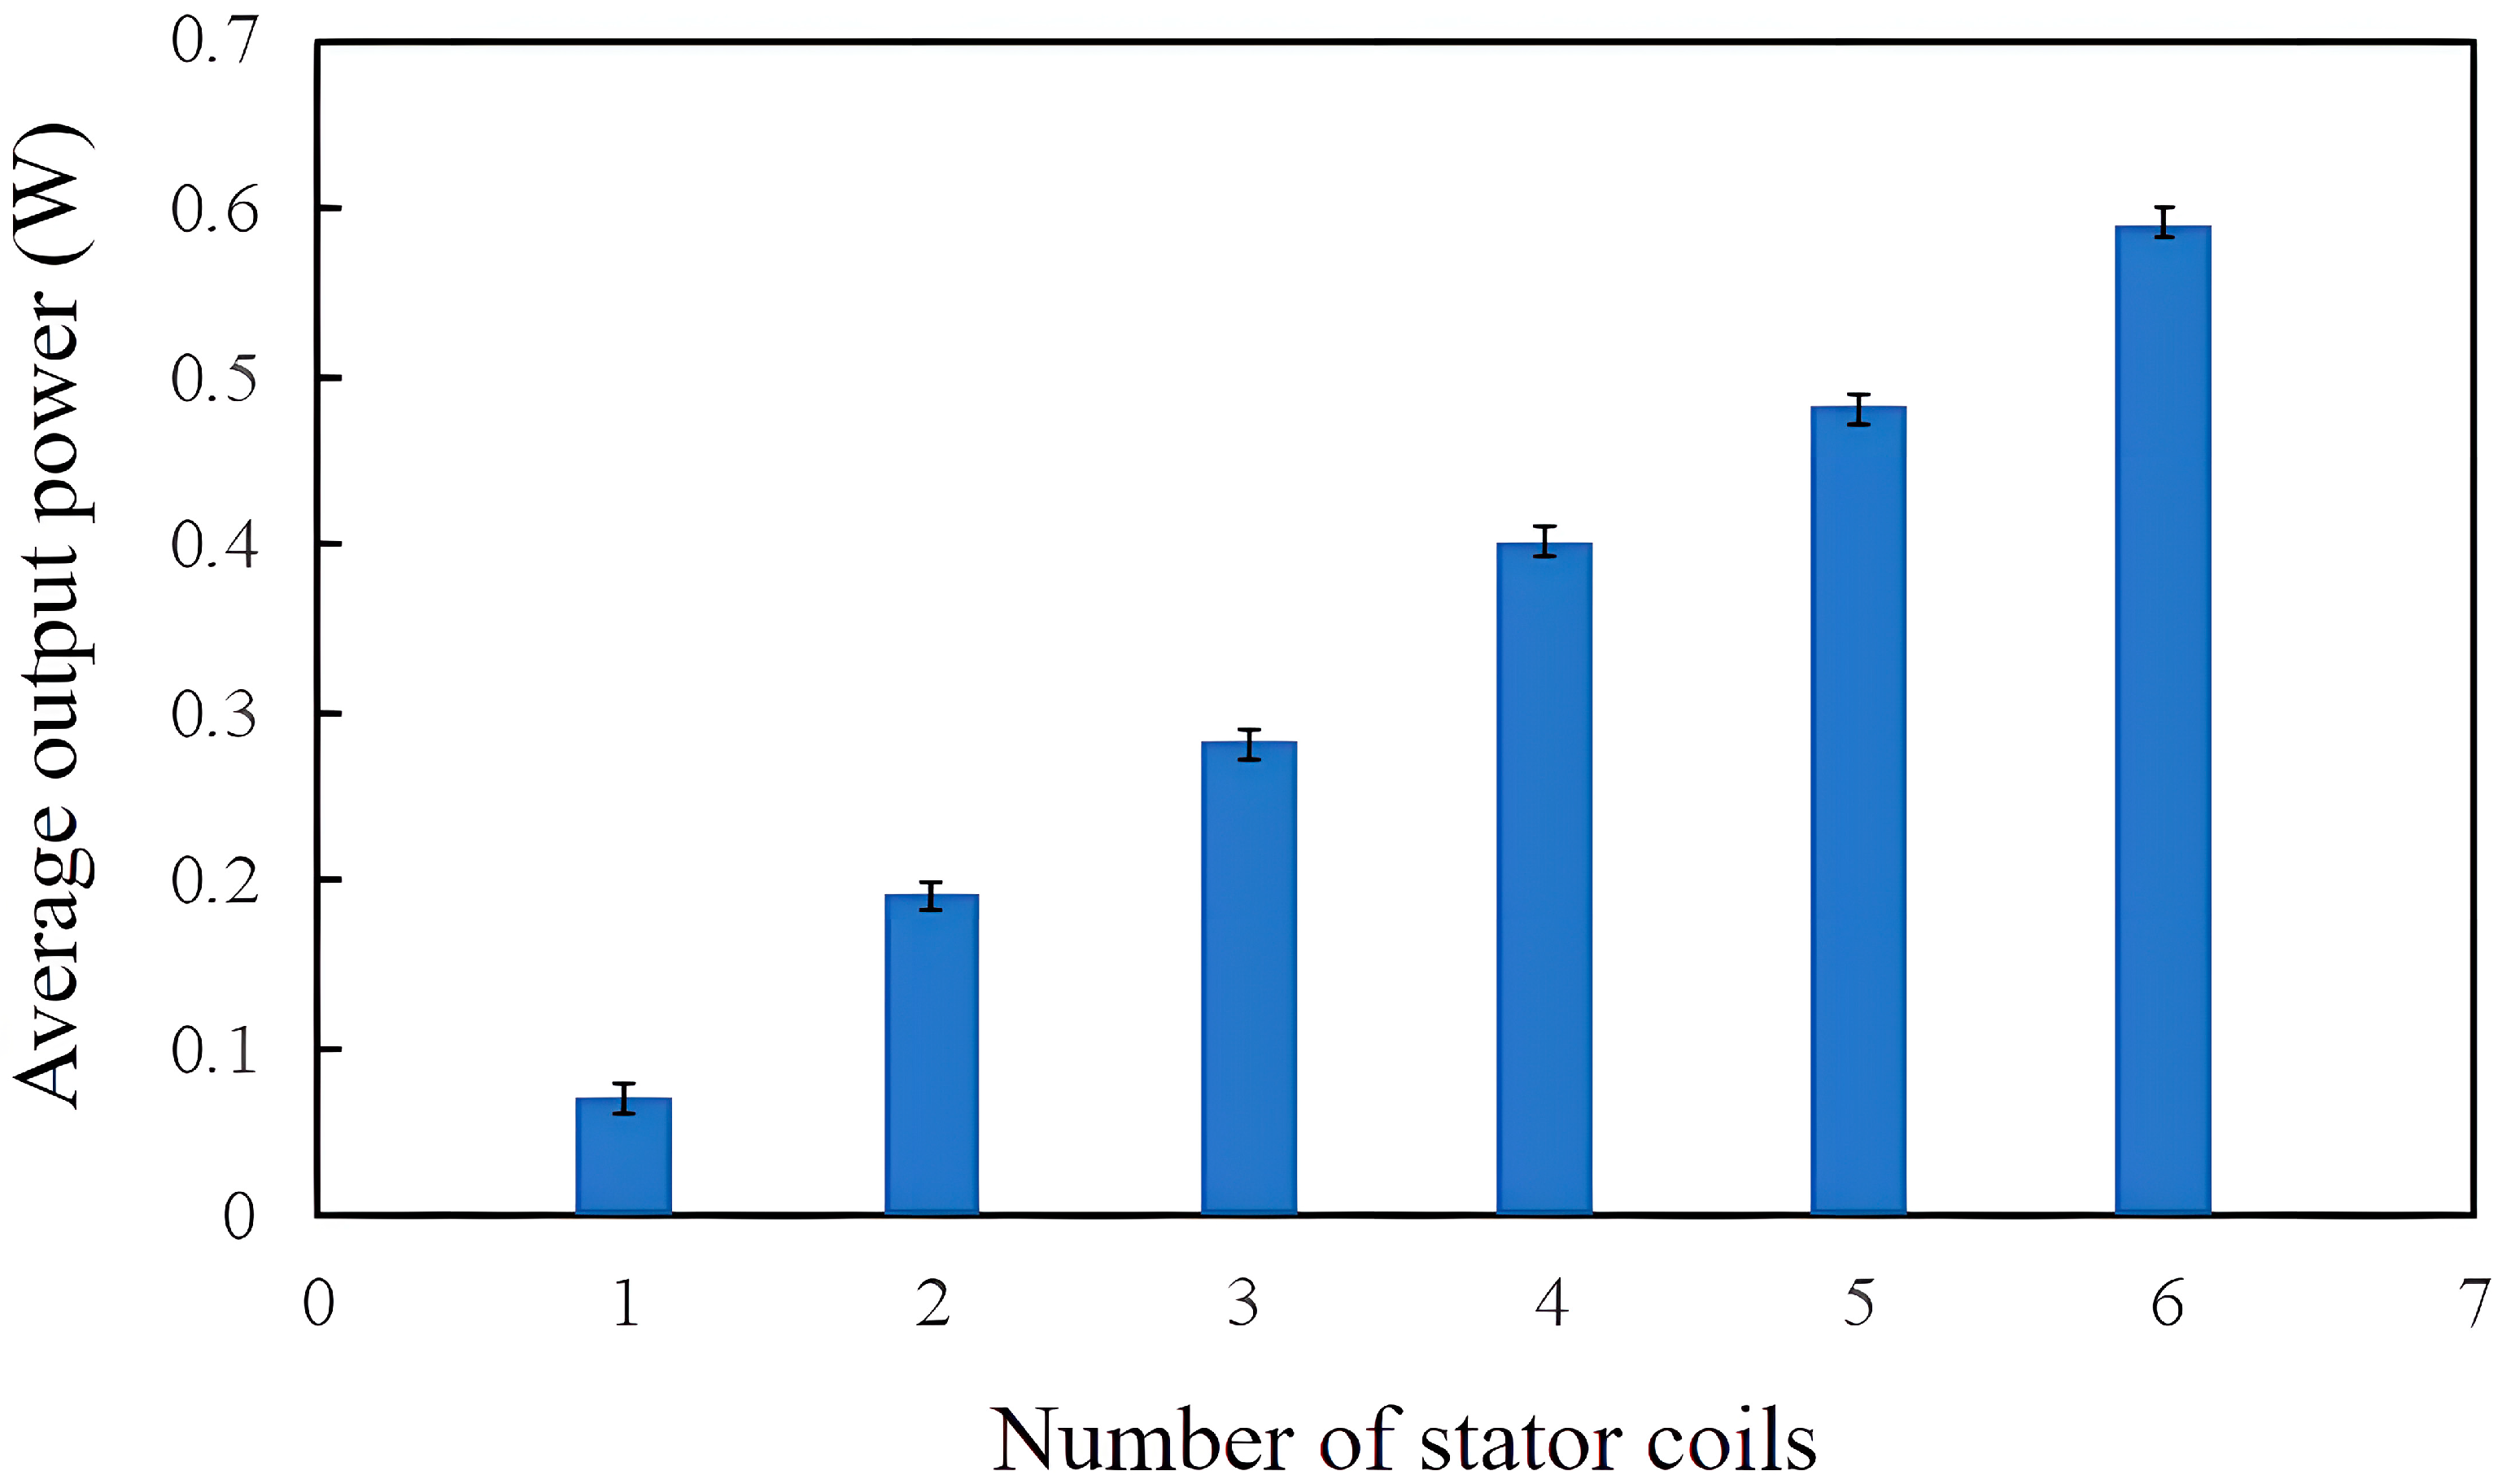
To study the effect of varying stator coil counts on the power output of the pulley-buoy-accelerated wave energy generation system under fixed wave conditions, relevant tests were conducted. Figure 5 presents the calculated relationship between the system’s average power output and the number of stator coils. As the number of coils increases from 1 to 6, the system’s average power output rises from 0.07 ± 0.01 W to 0.56 ± 0.01 W.
Figure 5.
Average output power of the system with different number of coils.
From this, it can be concluded that the system’s average power output exhibits a linear upward trend with an increase in the number of coils. This trend further confirms that increasing the number of stator coils effectively enhances the power generation performance of the pulley-buoy-accelerated wave energy generation system, thereby improving its wave energy conversion efficiency. This phenomenon indicates that the low-frequency and large stroke operating conditions of wave energy require compensation for voltage short boards by increasing the number of turns.
5.2. Effects of Wave Conditions and Buoy Sizes on Power Generation
In this experiment, with the linear power generation system configured to have five annular magnets and eight stator coils, a comparative study was conducted on two different sizes of spherical buoys under three distinct wave conditions. Among the buoys, two specific sizes have diameters of 500 mm and 310 mm, respectively. The three wave conditions are defined and listed in Table 2.
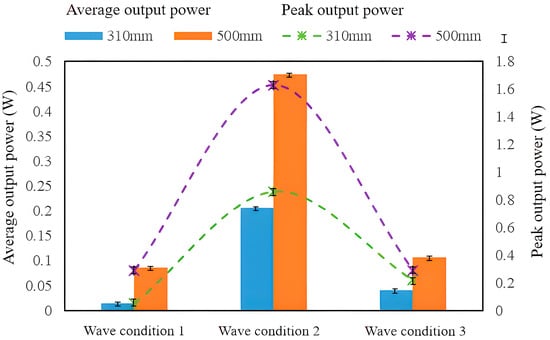
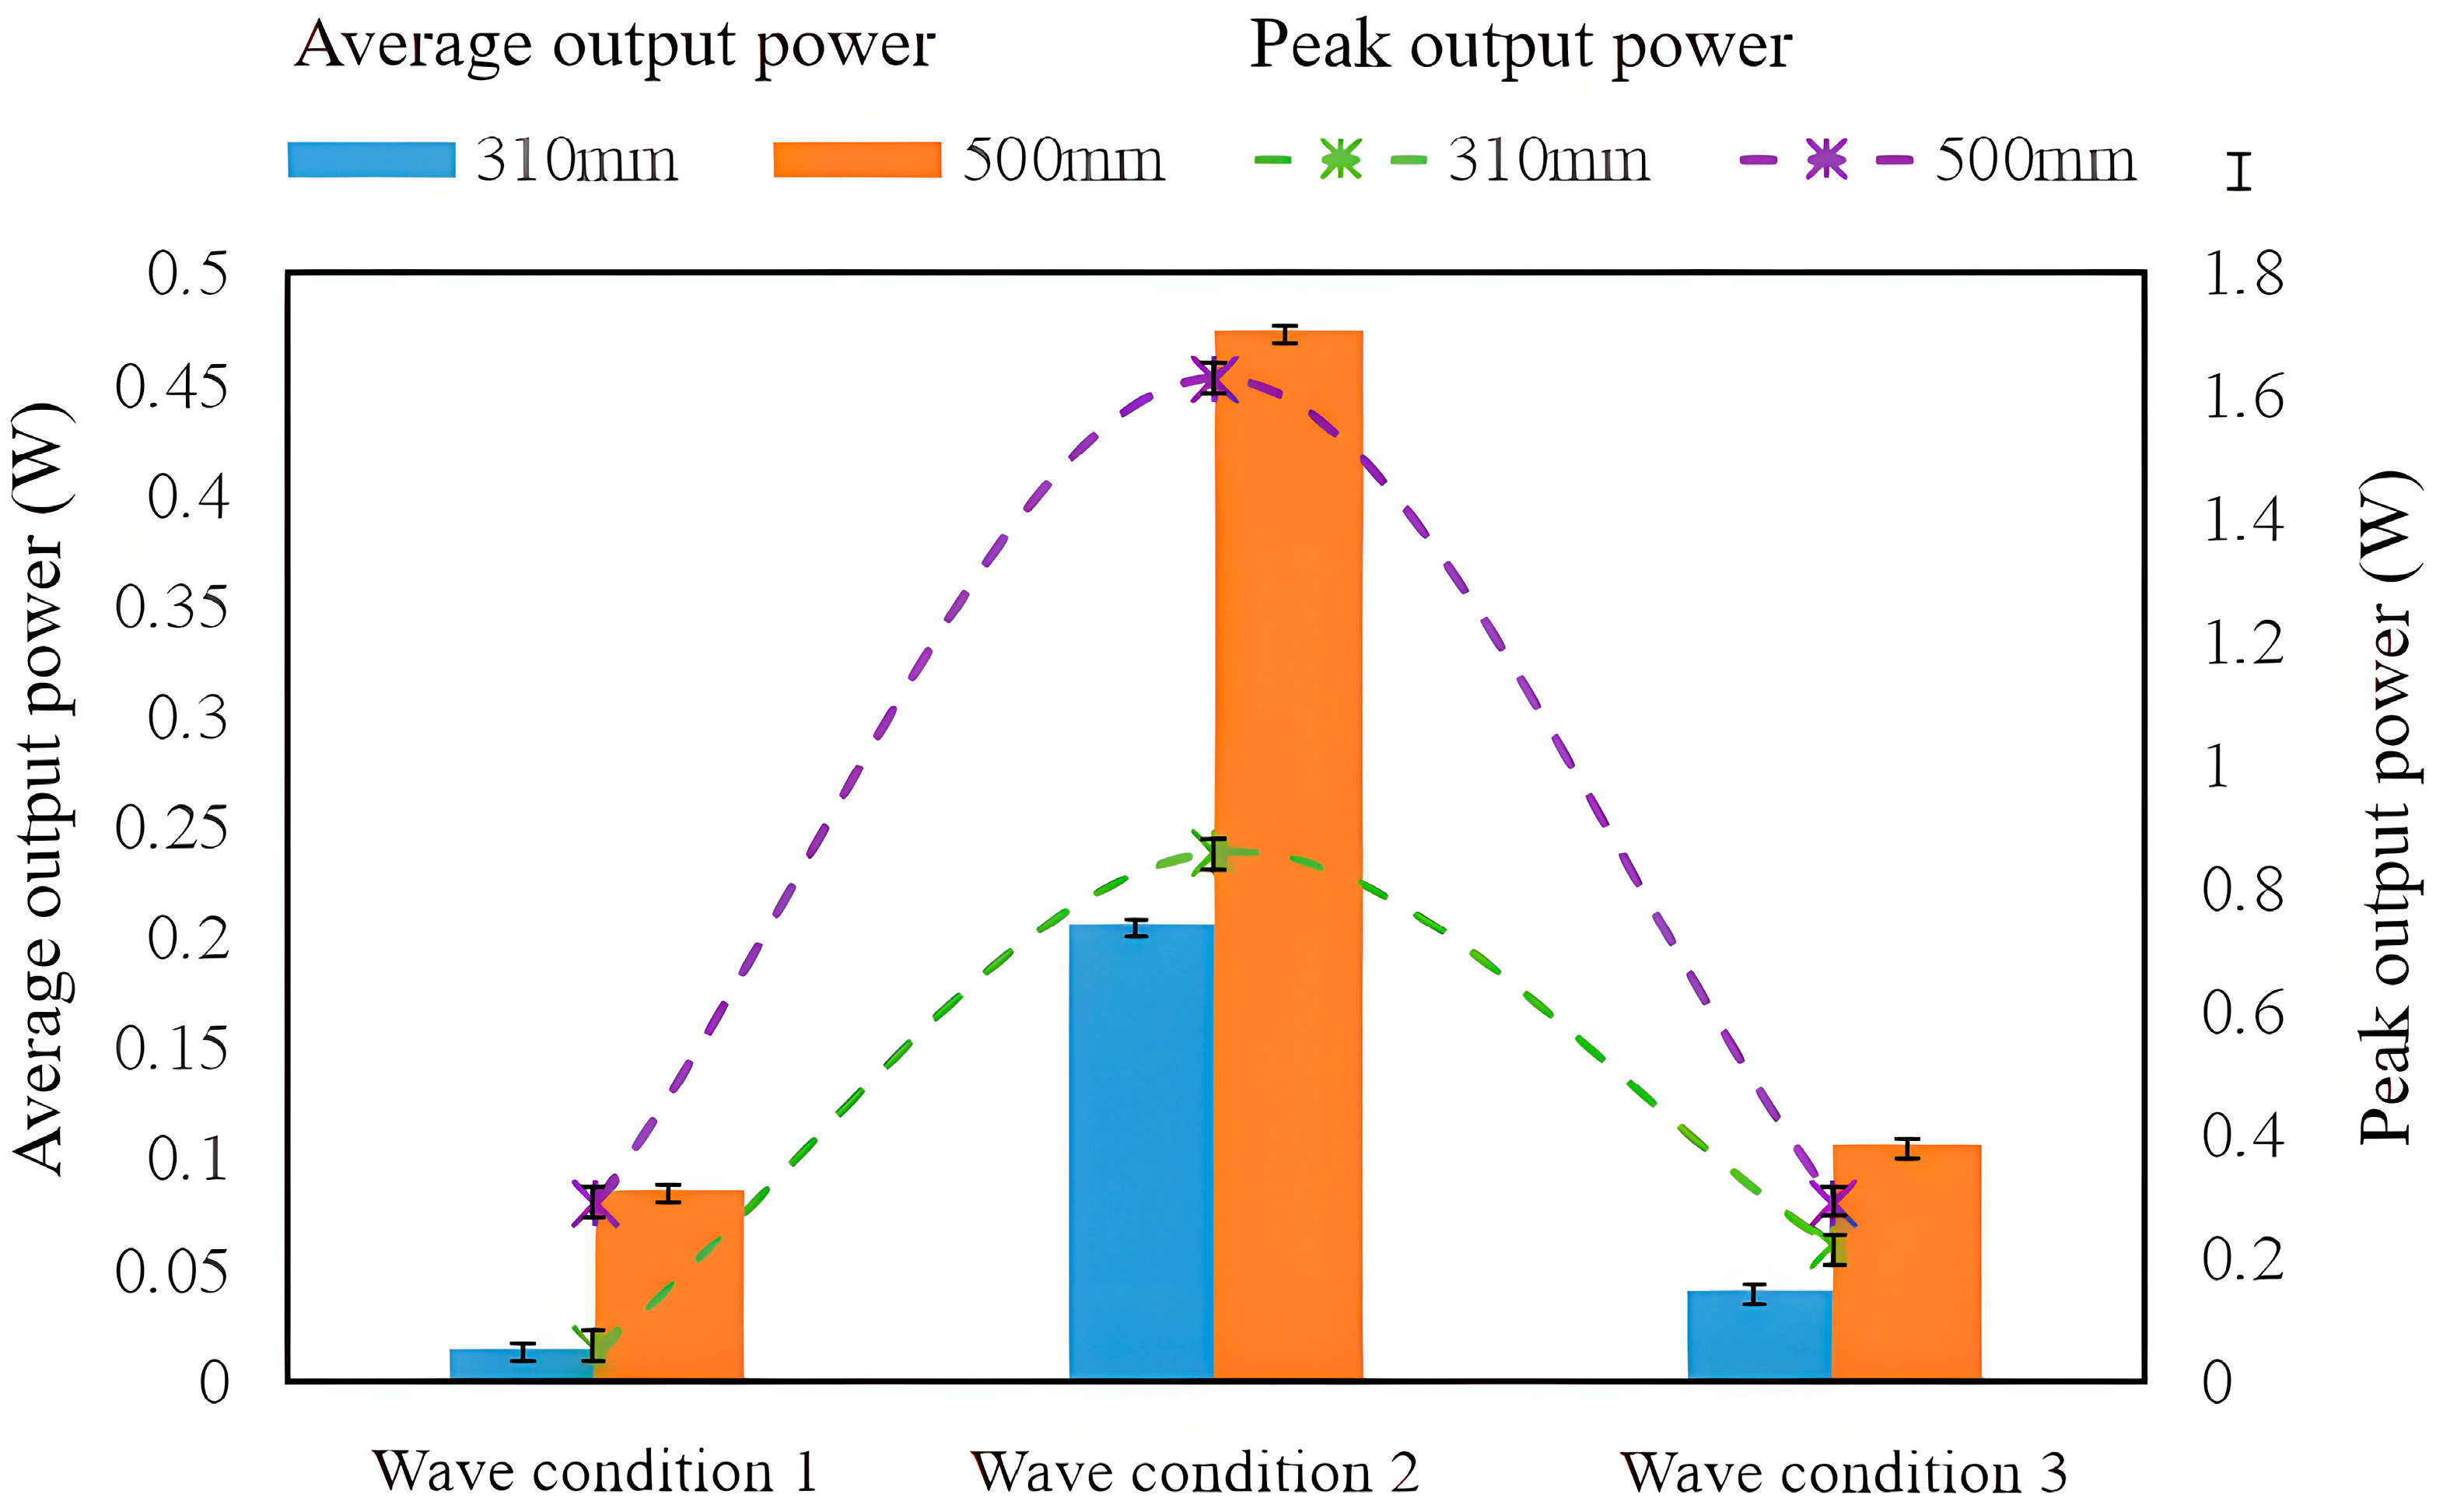
Figure 6 presents the comparison of average power output and peak power of spherical buoys with different sizes, with detailed results provided in Table 4. Energy conversion efficiency (e.g., absorbed power relative to incident wave power) is listed in Table 5. By analyzing the power generation performance of the 500 mm diameter and 310 mm diameter spherical buoys under the optimal wave condition (defined within this study as Wave Condition 2), it is observed that, under conditions of larger wave height, longer wavelength, and shorter wave period, the peak power output of the 500 mm diameter buoy is approximately 89.5% higher than that of the 310 mm diameter buoy. Additionally, the increase in average power is more significant, at approximately 130.6%.
Figure 6.
Comparison of average and peak values of output power for spherical buoys with different sizes.
Table 4.
Comparison experimental results of average and peak values of output power for spherical buoys with different sizes.
Table 5.
Comparison experimental results of energy conversion efficiency for spherical buoys with different sizes.
This indicates that, for the spherical buoys investigated in this study, increasing the buoy size within a certain range under fixed wave conditions can significantly enhance both the wave energy conversion efficiency and power generation performance of the pulley-buoy-accelerated wave energy generation system. The reason for this phenomenon is that small buoys are sensitive to the irregularity of waves (such as instantaneous wave height fluctuations and frequency changes), and their motion state is prone to “empty range” (such as speed below the generator start-up threshold) or “reverse motion”, resulting in “ineffective power generation”. Large buoys have greater inertia, lower motion damping, and can smooth the instantaneous fluctuations of waves.
6. Conclusions
To tackle the low wave energy conversion efficiency of traditional direct-drive WECs, this study proposes a pulley-buoy-accelerated linear wave energy conversion system. In this system, the oscillating buoy is directly coupled to the mover of the linear generator, facilitating the direct extraction of electrical energy from the wave-induced oscillatory motion of the buoy and eliminating intermediate energy transmission and conversion stages. Furthermore, the incorporation of a pulley mechanism amplifies the buoy’s motion speed, thereby multiplying the rate at which the mover cuts the magnetic field lines in the linear generator. This improvement enhances the generator’s electrical output power, ultimately elevating the system’s overall wave energy conversion efficiency.
To verify the feasibility and effectiveness of the pulley-buoy-accelerated linear wave energy generation system, a prototype and a swing-type wave-making system were constructed. Experimental studies on the prototype were conducted under laboratory conditions, focusing on the effects of stator coil count, wave conditions, and buoy size on the system’s power output. The key conclusions are as follows:
- (1)
- For the same buoy and fixed wave conditions, the system’s average power output shows a linear upward trend with an increase in the number of stator coils. Specifically, for a 650 mm diameter spherical buoy (with the number of annular magnets in the linear generator fixed at four), when the stator coil count increases from one to six, the system achieves a maximum average power output of approximately 0.56 ± 0.01 W during stable operation.
- (2)
- For the same buoy and fixed coil count, wave conditions with larger wave height, longer wavelength, and shorter wave period more effectively improve the power generation performance of the pulley-buoy-accelerated system. For example, with a 500 mm diameter spherical buoy (five annular magnets and eight stator coils in the linear generator), the system’s average power output reaches 0.472 ± 0.004 W under such optimal wave conditions.
- (3)
- For fixed wave conditions and coil count, appropriately increasing the buoy size significantly enhances the system’s power generation performance. Under the optimal wave condition (Wave Condition 2) defined in this study (with five annular magnets and eight stator coils), the 500 mm diameter spherical buoy exhibits an approximately 89.5% higher peak power output and a more significant 130.6% higher average power output compared to the 310 mm diameter buoy.
- (4)
- In summary, within the scope of this study, the following measures effectively improve the system’s wave energy conversion efficiency and power generation performance: increasing the number of stator coils, increasing wave height and wavelength, shortening wave period, and moderately enlarging the buoy size. The experiments confirm the feasibility and effectiveness of the pulley-buoy-accelerated linear wave energy generation system, providing valuable insights for the practical application and efficient operation of wave energy systems.
In future work, numerical simulation research on the device will be conducted to better obtain optimized parameters, thereby promoting its application in shore-based wave energy generation scenarios. And we will consider improving structural reliability, shore-based application, and full-scale validation in future work.
Author Contributions
Conceptualization, H.C. and Y.T.; methodology, B.D.; software, H.Z.; validation, C.F.; formal analysis, B.D.; investigation, H.Z.; resources, H.C.; data curation, B.D.; writing—original draft preparation, H.C.; writing—review and editing, Y.T.; visualization, C.F.; supervision, H.C.; project administration, H.C.; funding acquisition, Y.T. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the National Natural Science Foundation of China (Grant number: 42506217), the Fujian Provincial Natural Science Youth Funding (No. 2024J08195), the Xiamen Science and Technology Bureau Nature Funding (No. 3502Z202471046), and the Fujian Province Young and Middle-aged Teacher Education Research Project (Science and Technology) Key Project (No. JZ230027).
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
Appendix A. Essential Theoretical Foundations and Mathematical Models
Appendix A.1. Hydrodynamic Model
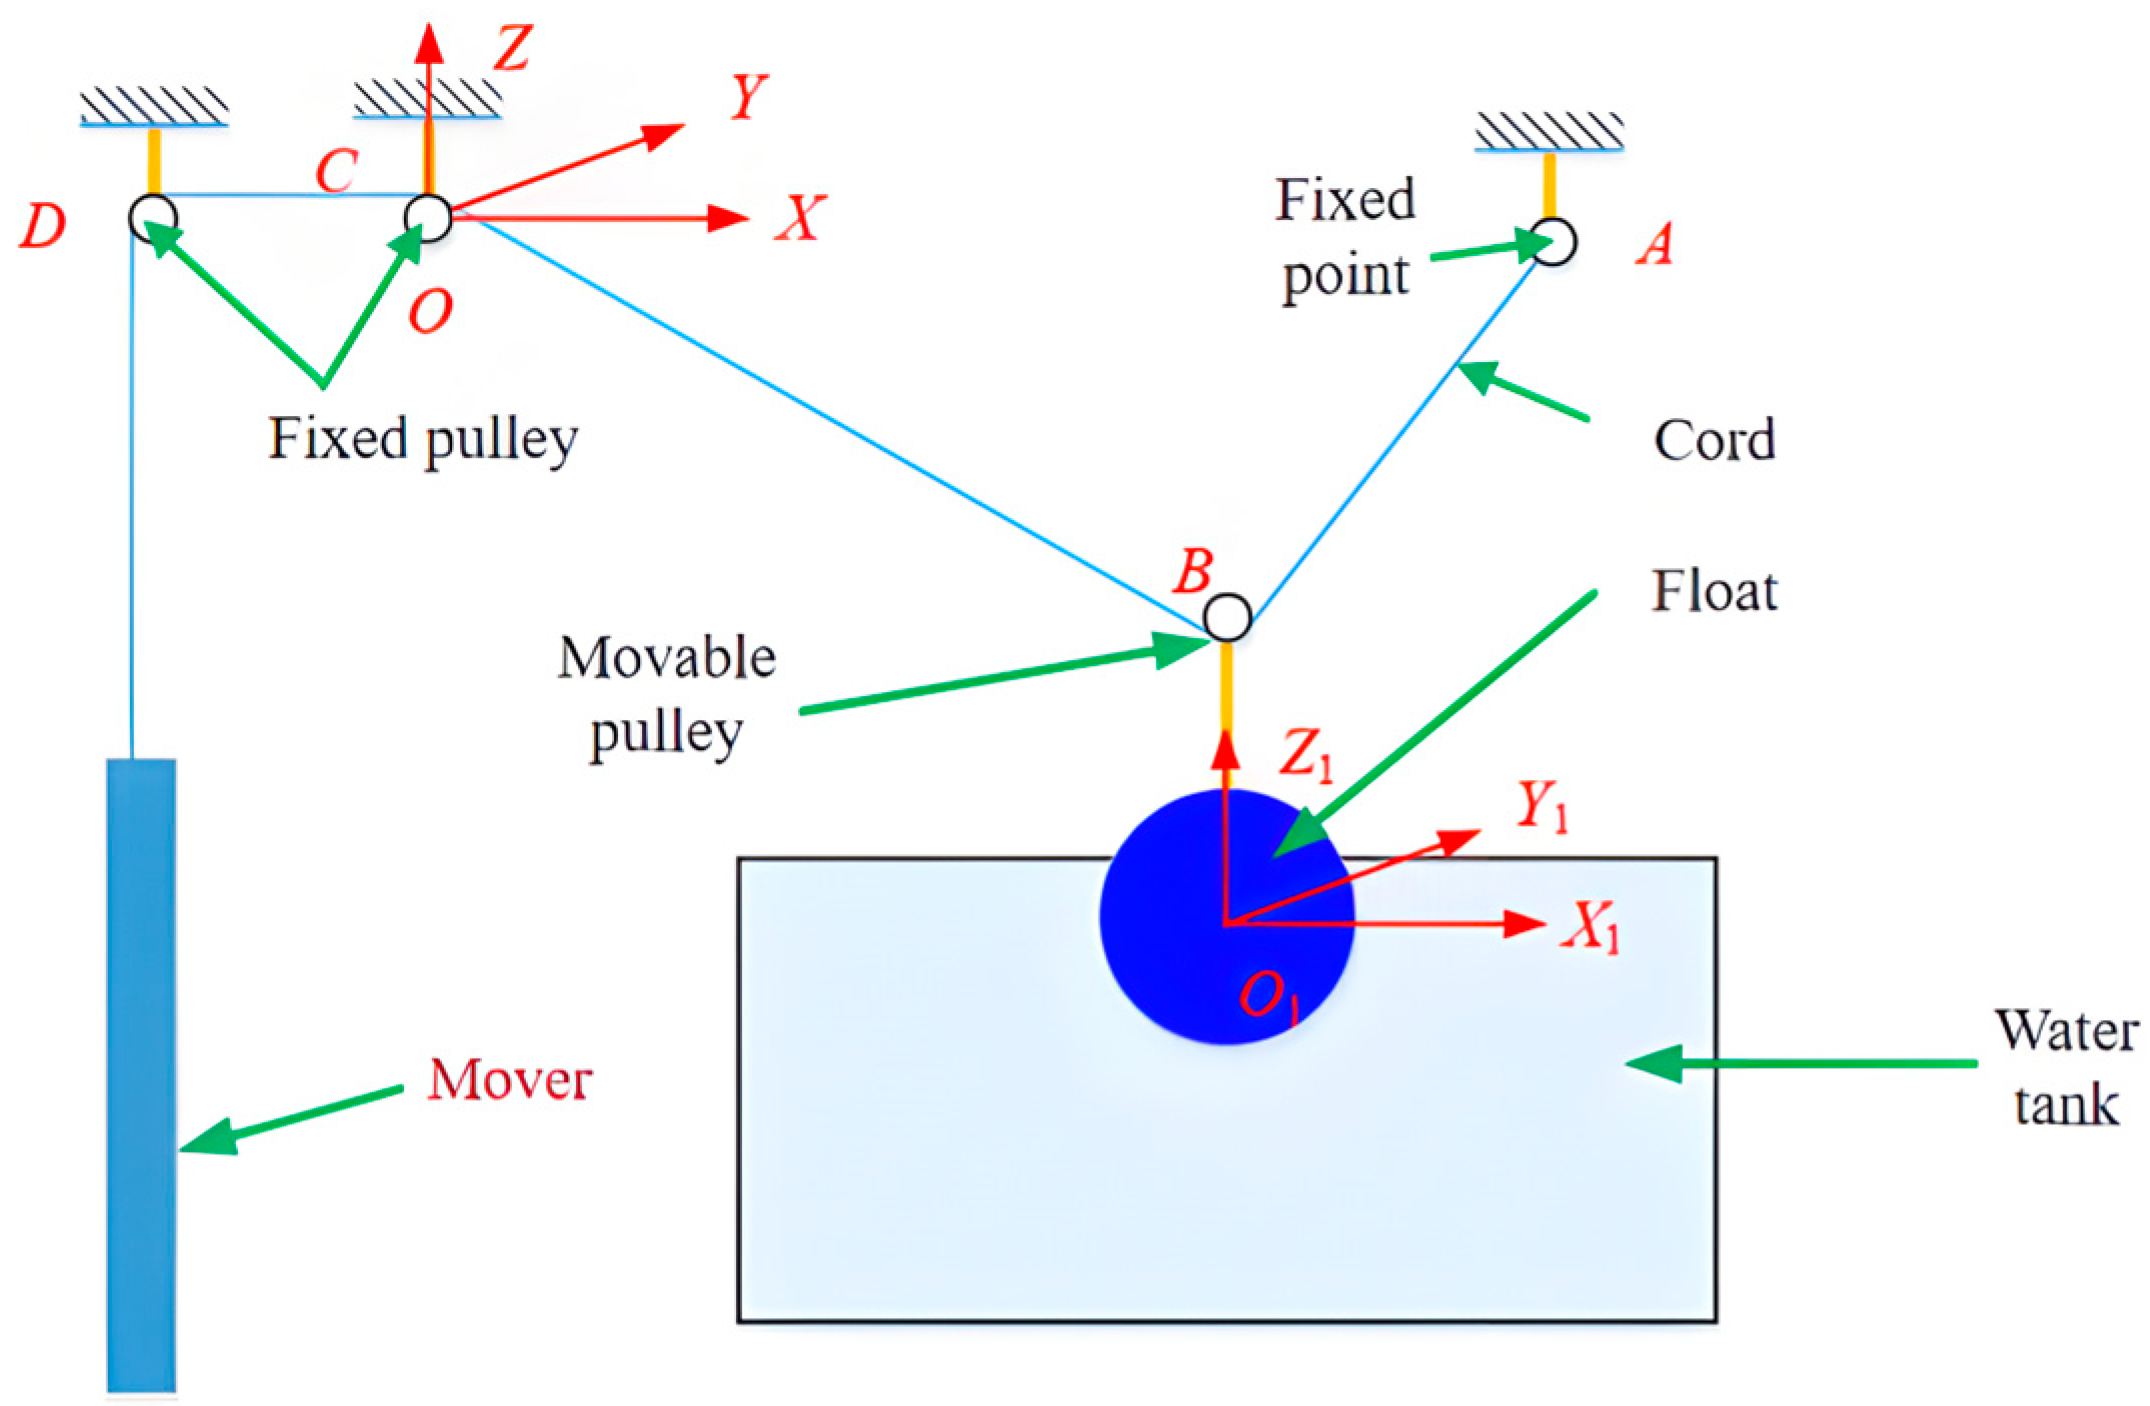
The ship maneuvering mathematical model group (MMG) model [30] is used to establish the hydrodynamic model of the proposed wave energy converter (WEC). First, the coordinate system is established as shown in Figure A1. is the fixed point. and are the fixed pulleys and is the movable pulley. The static coordinate system is established at the fixed pulley , the -axis direction points to the water tank, the -axis is upward, and the -axis direction can be determined by the right-hand rule. The dynamic coordinate system is established at the center of mass of the buoy. -axis, -axis, and -axis are fixed on the buoy and are parallel to -axis, -axis, and -axis when the buoy is stationary, respectively.
Figure A1.
Coordinate system and system design diagram of the proposed WEC.
The core principle of the MMG model lies in decomposing the hydrodynamic forces and moments acting on a ship into components exerted on the buoy, open-water propeller, and rudder. Subsequently, by applying Newton’s second law to these three components (buoy, open-water propeller, and rudder), the mathematical model of ship motion is derived.
For the WEC investigated in this study, its buoy can be analogous to the buoy of a ship, while the device system itself lacks both a propeller and a rudder. Accordingly, the hydrodynamic model for the wave energy-harvesting system with wave aggregation and speed augmentation can be established by leveraging the MMG model framework—specifically, by omitting the force components associated with the propeller and rudder, and incorporating the dynamic effect of the linear generator on the buoy.
Taking the buoy as the research object, based on the MMG separation model, the general form of the buoy motion equation can be written as follows.
where is the mass of the buoy. is the acceleration of gravity. ( = , , ) is the added mass in direction . is the rotational inertia of the buoy around the axis. is the additional moment of inertia of the buoy around the i axis. , , and are the rotation angular velocity of the buoy around the -axis, -axis, and -axis, respectively. is the projection of wave force on the axis, while is the wave moment around the axis received by the buoy. is the component of the elastic force on the buoy in the axis. is the torque of the elastic force around the axis. and are the damping force along the axis and the damping moment around the axis, respectively. , , and are the speed of buoy in surge, sway, and heave direction, respectively.
In Equation (A1), , , , , , and are the rotation and translation speeds of the buoy in the coordinate system . In order to solve Equation (A1), it is still necessary to establish the auxiliary equation of the buoy movement, that is, , , , , , and are described by the generalized variables in the coordinate system . Since the buoy has six degrees of freedom, six generalized variables are needed to describe the motion of the buoy. The generalized variable is selected as . , , and represent the coordinates of the center of mass of the buoy in the coordinate system , respectively. , , are the rotation angles of the coordinate system around the -axis, -axis, and -axis. The rotation matrix of buoy can be written as follows.
The motion auxiliary equation is as follows.
Then, the force and moment on the buoy, including wave force, moment, damping force, and moment, are calculated. Based on the Froude–Krylov hypothesis, under the action of linear waves, the wave force and wave moment on the buoy can be calculated by the Equations (A4) and (A5), respectively [31].
In Equations (A4) and (A5), is the angular frequency of the wave. is the wave encounter angle. is the wave number, and is the draft of the buoy.
The damping of the buoy during its movement mainly includes linear damping, radiation damping, and power output damping. The damping force and torque on the buoy can be written as follows.
where , , and are linear damping coefficients in , , and direction, respectively. , , and are radiation damping coefficients in , , and direction, respectively. , , and are the damping coefficients rotating around the , , and direction, respectively.
Finally, the motion model of the buoy can be obtained as follows.
where = ; = ; = ; = ; = ; = ; = ; = ; =. is the mass matrix, is the inertia term of the dynamic model. It can be seen from Equation (A7) that the dynamic model of the proposed WEC is a second-order differential equation system with six variables. Given the initial conditions, it can be solved numerically by Runge–Kutta method. Wave force can be written as follows.
where is the wave excitation force. is wave radiation force.
Appendix A.2. Generating Power
Since the electric energy generated by the rotation of the buoy is very small, this study focuses on the translational kinetic energy of the buoy. In the coordinate system , the coordinates of movable pulley B can be expressed as follows.
where is the coordinate of movable pulley in the coordinate system , and its form is as follows.
where is the distance from the movable pulley to the center of the buoy. Assuming that the distance between fixed point A and fixed pulley is , the length of cord between and is as follows.
Therefore, the velocity of the mover can be expressed as follows.
Since the movement speed of the mover is vertical to the coil, the induced electromotive force generated by the coil cutting magnetic line of force is as follows.
where is the length of the coil and is the magnetic induction strength. Assuming that the resistance of the coil is , the final generating power of the WEC can be calculated as follows.
References
- Martínez, M.L.; Vázquez, G.; Pérez-Maqueo, O.; Silva, R.; Moreno-Casasola, P.; Mendoza-González, G.; López-Portillo, J.; MacGregor-Fors, I.; Heckel, G.; Hernández-Santana, J.R.; et al. A systemic view of potential environmental impacts of ocean energy production. Renew. Sustain. Energy Rev. 2021, 149, 111332. [Google Scholar] [CrossRef] [Scilit]
- Hu, H.; Xue, W.; Jiang, P.; Li, Y. Bibliometric analysis for ocean renewable energy: An comprehensive review for hotspots, frontiers, and emerging trends. Renew. Sustain. Energy Rev. 2022, 167, 112739. [Google Scholar] [CrossRef] [Scilit]
- Falcão, A.F.O.; Henriques, J.C.C. Oscillating-water-column wave energy converters and air turbines: A review. Renew. Energy 2016, 85, 1391–1424. [Google Scholar] [CrossRef] [Scilit]
- Foteinis, S. Wave energy converters in low energy seas: Current state and opportunities. Renew. Sustain. Energy Rev. 2022, 162, 112448. [Google Scholar] [CrossRef] [Scilit]
- Rosati, M.; Henriques, J.C.C.; Ringwood, J.V. Oscillating-water-column wave energy converters: A critical review of numerical modelling and control. Energy Convers. Manag. X 2022, 16, 100322. [Google Scholar] [CrossRef] [Scilit]
- Yang, B.; Duan, J.; Chen, Y.; Wu, S.; Li, M.; Cao, P.; Jiang, L. A critical survey of power take-off systems based wave energy converters: Summaries, advances, and perspectives. Ocean Eng. 2024, 298, 117149. [Google Scholar] [CrossRef] [Scilit]
- Everett, J.; Sorokin, V.; Whittaker, C.; Aw, K. Numerical and experimental analysis of the power output performance of a point absorber WEC for nearshore wave conditions. Ocean Eng. 2024, 309, 118381. [Google Scholar] [CrossRef] [Scilit]
- Yang, S.; Zhang, C.; Du, Z.; Tu, Y.; Dai, X.; Huang, Y.; Fan, J.; Hong, Z.; Jiang, T.; Wang, Z.L. Fluid Oscillation-Driven Bi-Directional Air Turbine Triboelectric Nanogenerator for Ocean Wave Energy Harvesting. Adv. Energy Mater. 2024, 14, 2304184. [Google Scholar] [CrossRef] [Scilit]
- Yang, S.; Zhu, W.; Tu, Y.; Cao, G.; Chen, X.; Du, Z.; Fan, J.; Huang, Y. Study on the influence of heave plate on energy capture performance of central pipe oscillating water column wave energy converter. Energy 2024, 312, 133517. [Google Scholar] [CrossRef] [Scilit]
- Phan, C.B.; Ahn, K.K. Experimental Investigation of a Point Absorber Wave Energy Converter Using an Inertia Adjusting Mechanism. Appl. Sci. 2024, 14, 5506. [Google Scholar] [CrossRef] [Scilit]
- Tao, T.; Deng, Z.; Li, M.; Cheng, P.; Luo, W. Numerical and Experimental Study on the Hydrodynamic Performance of a Sloping OWC Wave Energy Converter Device Integrated into Breakwater. J. Mar. Sci. Eng. 2024, 12, 2318. [Google Scholar] [CrossRef] [Scilit]
- Wang, C.; Wei, Y.; Chen, W.; Huang, L. Hydroelastic modelling of a deformable wave energy converter including power take-off. Mar. Struct. 2024, 98, 103678. [Google Scholar] [CrossRef] [Scilit]
- Shadmani, A.; Nikoo, M.R.; Gandomi, A.H.; Chen, M.; Nazari, R. Advancements in optimizing wave energy converter geometry utilizing metaheuristic algorithms. Renew. Sustain. Energy Rev. 2024, 197, 114398. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.; Yang, S.; Dai, X.; Tu, Y.; Du, Z.; Wu, X.; Huang, Y.; Fan, J.; Hong, Z.; Jiang, T.; et al. Hybridized triboelectric-electromagnetic nanogenerators for efficient harvesting of wave energy for self-powered ocean buoy. Nano Energy 2024, 128, 109929. [Google Scholar] [CrossRef] [Scilit]
- Asiikkis, A.T.; Grigoriadis, D.G.E.; Vakis, A.I. Wave-to-wire modelling and hydraulic PTO optimization of a dense point absorber WEC array. Renew. Energy 2024, 237, 121620. [Google Scholar] [CrossRef] [Scilit]
- Fenu, B.; Henriques, J.C.C.; Glorioso, M.; Gato, L.M.C.; Bonfanti, M. Real-time Wells turbine simulation on an oscillating-water-column wave energy converter physical model. Appl. Energy 2024, 376, 124121. [Google Scholar] [CrossRef] [Scilit]
- Rezaei, S.; Rahimi, A.; Parvizian, J.; Mansoorzadeh, S.; Düster, A. A rectified unidirectional rotary PTO for two-body wave energy converters. Ocean Eng. 2023, 279, 114507. [Google Scholar] [CrossRef] [Scilit]
- Chang, X.; Huang, L.; Zhang, X.; Yang, J.; Liu, H. Study on the Dynamic Optimal Control Strategy of an Electric-Hydrogen Hybrid Energy Storage System for a Direct Drive Wave Power Generation System. J. Mar. Sci. Eng. 2023, 11, 1347. [Google Scholar] [CrossRef] [Scilit]
- Huang, L.; Wang, S.; Pan, B.; Liu, H.; Zhang, J.; Wu, S. Research on Decoupling Duty Cycle Optimization Control Method of a Multiport Converter for Dual-Port Direct Drive Wave Power Generation System. J. Mar. Sci. Eng. 2024, 12, 1811. [Google Scholar] [CrossRef] [Scilit]
- Wu, S.; Huang, L.; Yang, J.; Zhang, J.; Liu, H.; Wang, S.; Mou, Z. Research on Fourier Coefficient-Based Energy Capture for Direct-Drive Wave Energy Generation System Based on Position Sensorless Disturbance Suppression. J. Mar. Sci. Eng. 2024, 12, 1358. [Google Scholar] [CrossRef] [Scilit]
- Ghaheri, A.; Afjei, E.; Torkaman, H. Design optimization of a novel linear transverse flux switching permanent magnet generator for direct drive wave energy conversion. Renew. Energy 2022, 198, 851–860. [Google Scholar] [CrossRef] [Scilit]
- Dang, T.D.; Do, T.C.; Ahn, K.K. Design and experiment of a direct-drive wave energy converter using a variable stiffness mechanism. Ocean Eng. 2022, 266, 112841. [Google Scholar] [CrossRef] [Scilit]
- Lin, Y.; Wang, N.; Hui, X.; Karimi, H.R.; Liu, S. Finite-time cascade-like tracking control of direct-drive wave energy converters. Ocean Eng. 2022, 266, 112622. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Huang, L.; Chen, M.; Tan, P.; Hu, M. Maximum power point tracking control based on inertia force for underwater direct-drive wave energy converter. Renew. Energy 2023, 215, 118964. [Google Scholar] [CrossRef] [Scilit]
- Liu, H.; Huang, L.; Li, Y.; Yang, J.; Zhang, J. Resonance control to eliminate reactive power of an improved dual-port direct-drive wave energy converter. Ocean Eng. 2023, 288, 116007. [Google Scholar] [CrossRef] [Scilit]
- Dong, S.; Wu, Z. Prescribed performance adaptive MPPT control of direct-drive wave energy generation system. Ocean Eng. 2024, 298, 117066. [Google Scholar] [CrossRef] [Scilit]
- Yang, J.; Huang, L.; Wu, S.; Liu, H.; Zhang, J.; Wang, Y. Approximate optimal condition model-free predictive velocity control of a direct-drive wave energy converter based on ultra-local model. Ocean Eng. 2024, 307, 118214. [Google Scholar] [CrossRef] [Scilit]
- Chen, H.; Ji, Z.; Hu, Y.; Lin, M. Influence of Buoy Size on Accelerated Wave Power Generation Device. E3S Web Conf. 2021, 271, 01023. [Google Scholar] [CrossRef] [Scilit]
- Peng, Y.; Wei, Y.; Zhou, M. Efficient modeling of cable-pulley system with friction based on arbitrary-Lagrangian-Eulerian approach. Appl. Math. Mech. 2017, 38, 1785–1802. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; el Moctar, O. A mathematical model for ships maneuvering in deep and shallow waters. Ocean Eng. 2024, 295, 116927. [Google Scholar] [CrossRef] [Scilit]
- Yu, Y.; Zhu, R.; Xu, D.; Huang, S.; Hong, L. Investigation into the direct calculation of added wave resistance of ship in forward motion with reflection ratio correction. Ocean Eng. 2021, 239, 109857. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.