


Abstract
To address the challenges of high cost, complex deployment, and difficulties in real-time early warning for small landslides near residential areas, a portable and low-cost high-frequency monitoring device based on Micro-Electro-Mechanical Systems (MEMSs) was developed, and an advanced warning algorithm based on anomaly intensity factors was constructed. The device is easy to install and can collect and transmit data to the cloud in real time. Equipped with edge computing capabilities, it can independently analyze data in the absence of network connectivity and transmit real-time early warning information to terminals within a range of 5 km. To verify the performance of the system, a large-scale outdoor landslide simulation test site was constructed, where slope failure was induced through artificial rainfall to obtain the complete process data from deformation to failure. The experimental results demonstrate that the proposed early warning algorithm effectively identified different stability levels, providing warnings up to 13 s prior to catastrophic failure, confirming the high sensitivity and reliability of the device. This study offers a cost-effective and efficient approach to landslide monitoring and early warning, with notable prospects for broader implementation in practice.
1. Introduction
Landslides constitute a pervasive and devastating global geological hazard, threatening communities, infrastructure, and economic stability worldwide. Triggered by factors such as intense rainfall, seismic activity, and human modification of slopes, they cause thousands of fatalities and billions of dollars in losses annually, particularly in mountainous and rainfall-sensitive regions [1]. China, with its vast and varied terrain and pronounced climatic variability, represents one of the countries most severely affected by these disasters, harboring the largest exposed population globally [2]. Geological hazards such as landslides, rockfalls, and debris flows are widespread across China, frequently endangering communities and critical infrastructure [3]. Mountainous areas comprise nearly two-thirds of the nation’s land area, approximately 6.636 million km2 [4,5]. The geological setting of mountainous cities is inherently fragile, and when combined with frequent human engineering activities and extreme rainfall, landslide disasters occur with particularly high frequency in these regions. Beyond major and colossal landslides, a multitude of small- to medium-sized slope instabilities are distributed extensively around residential areas in both urban and rural settings [6,7]. These hazards are often concealed and pose a direct threat to dispersed populations, exemplifying the characteristic of “small-scale events causing significant damage”. Consequently, implementing effective and precise monitoring and early warning for these widely distributed, community-proximal slope hazards has emerged as a pressing priority within contemporary geological disaster prevention frameworks and is vital for bolstering disaster resilience at the community level [8].
In response, China has established a disaster prevention system integrating community-based and professional monitoring [9]. Significant progress has been made in deploying widely applicable devices, including Global Navigation Satellite System (GNSS) [10], crack meters [11], inclinometers [12], and rain gauges [13]. These technologies have demonstrated notable effectiveness. For instance, while monitored zones cover less than 1% of China’s territory, the deployed systems have contributed to timely warnings for nearly 20% of geological hazard incidents, significantly reducing casualties [14]. The full potential of such monitoring, however, is realized only when the data provide insights into failure mechanisms. Retrospective analysis of data from instruments like GNSS has proven invaluable for establishing rainfall thresholds, identifying precursor deformation patterns, and calibrating models—a cornerstone “learning from past failures” paradigm for proactive risk management [15].
However, the widespread application of this paradigm is critically limited by the inherent constraints of conventional monitoring systems. GNSS sensors, while precise, entail high costs, strict installation requirements (e.g., open-sky conditions), substantial data-processing needs, and dependence on reliable communication links, which hinder dense deployment in complex mountainous terrains [16]. Similarly, other point-based sensors face challenges in achieving broad spatial coverage. This limitation is acute in regions like Chongqing, where approximately 80% of geological disasters are sudden, newly developed events, and many potential sites remain unidentified and thus uncovered by traditional monitoring [17,18]. Consequently, the sparse data from high-cost systems restrict the acquisition of sufficient precursor information from the vast number of potential failure slopes, forming a major bottleneck in shifting from passive response to proactive prevention.
To overcome this bottleneck, the core challenge is to develop a new type of monitoring device that is low-cost, miniaturized, easy to deploy, and capable of near real-time signal transmission and intelligent interpretation [19]. The maturity of Micro-Electro-Mechanical System (MEMS) sensor technology offers a promising pathway. By integrating MEMS accelerometers and gyroscopes into an inertial measurement unit and leveraging edge computing, data preprocessing and feature extraction can be performed on the terminal, reducing reliance on communication bandwidth and enabling broader coverage [20]. Operationally, this technological shift must be coupled with a managerial evolution—from a passive model targeting known hazards to a proactive model overseeing potential risk areas [21]. This requires refined supervision of numerous spots identified through investigations. Therefore, the proposed solution is designed with a two-unit architecture: a professional monitoring unit deployed on slopes and a dedicated alarm unit placed within the community. This design enables deep integration with community-based systems by providing residents with an intuitive interface to receive real-time warnings, thereby directly enhancing situational awareness and autonomous response capacity.
The imperative for such innovation is amplified by global and national commitments to disaster risk reduction. Internationally, the UN Sendai Framework and the Sustainable Development Goals, particularly Goals 11 and 13, underscore the need for accessible early warning systems [22]. Nationally, China’s strategy emphasizes building a comprehensive monitoring and warning system, explicitly advocating for extending professional monitoring to grassroots levels and enhancing public self-rescue capabilities [23]. Developing a low-cost, community-integratable solution directly supports these directives by bridging the gap between professional monitoring and public alerting.
To address the aforementioned technological gap and strategic needs, this study developed a novel, high-frequency landslide monitoring device based on MEMS sensors, termed the Geological MEMS Alert System (GeoMAS). The system adopts a high-performance MEMS sensing unit as its core, featuring low cost, easy deployment, and low power consumption. A real-time early warning method is proposed, integrating edge computing on the terminal with cloud-based intelligent analysis [24]. Through multi-source data fusion and model-driven assessment in the cloud, the system supports timely landslide risk decision-making. The subsequent sections present the system design, a proposed early-warning methodology, and validation through large-scale outdoor tests to evaluate its detection and warning capabilities.
2. Monitoring Device
2.1. Basic Characteristics of the Monitoring Device
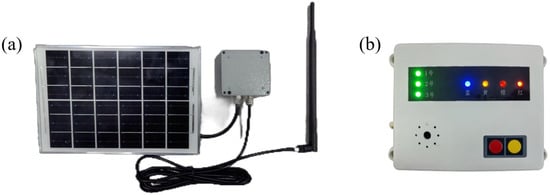
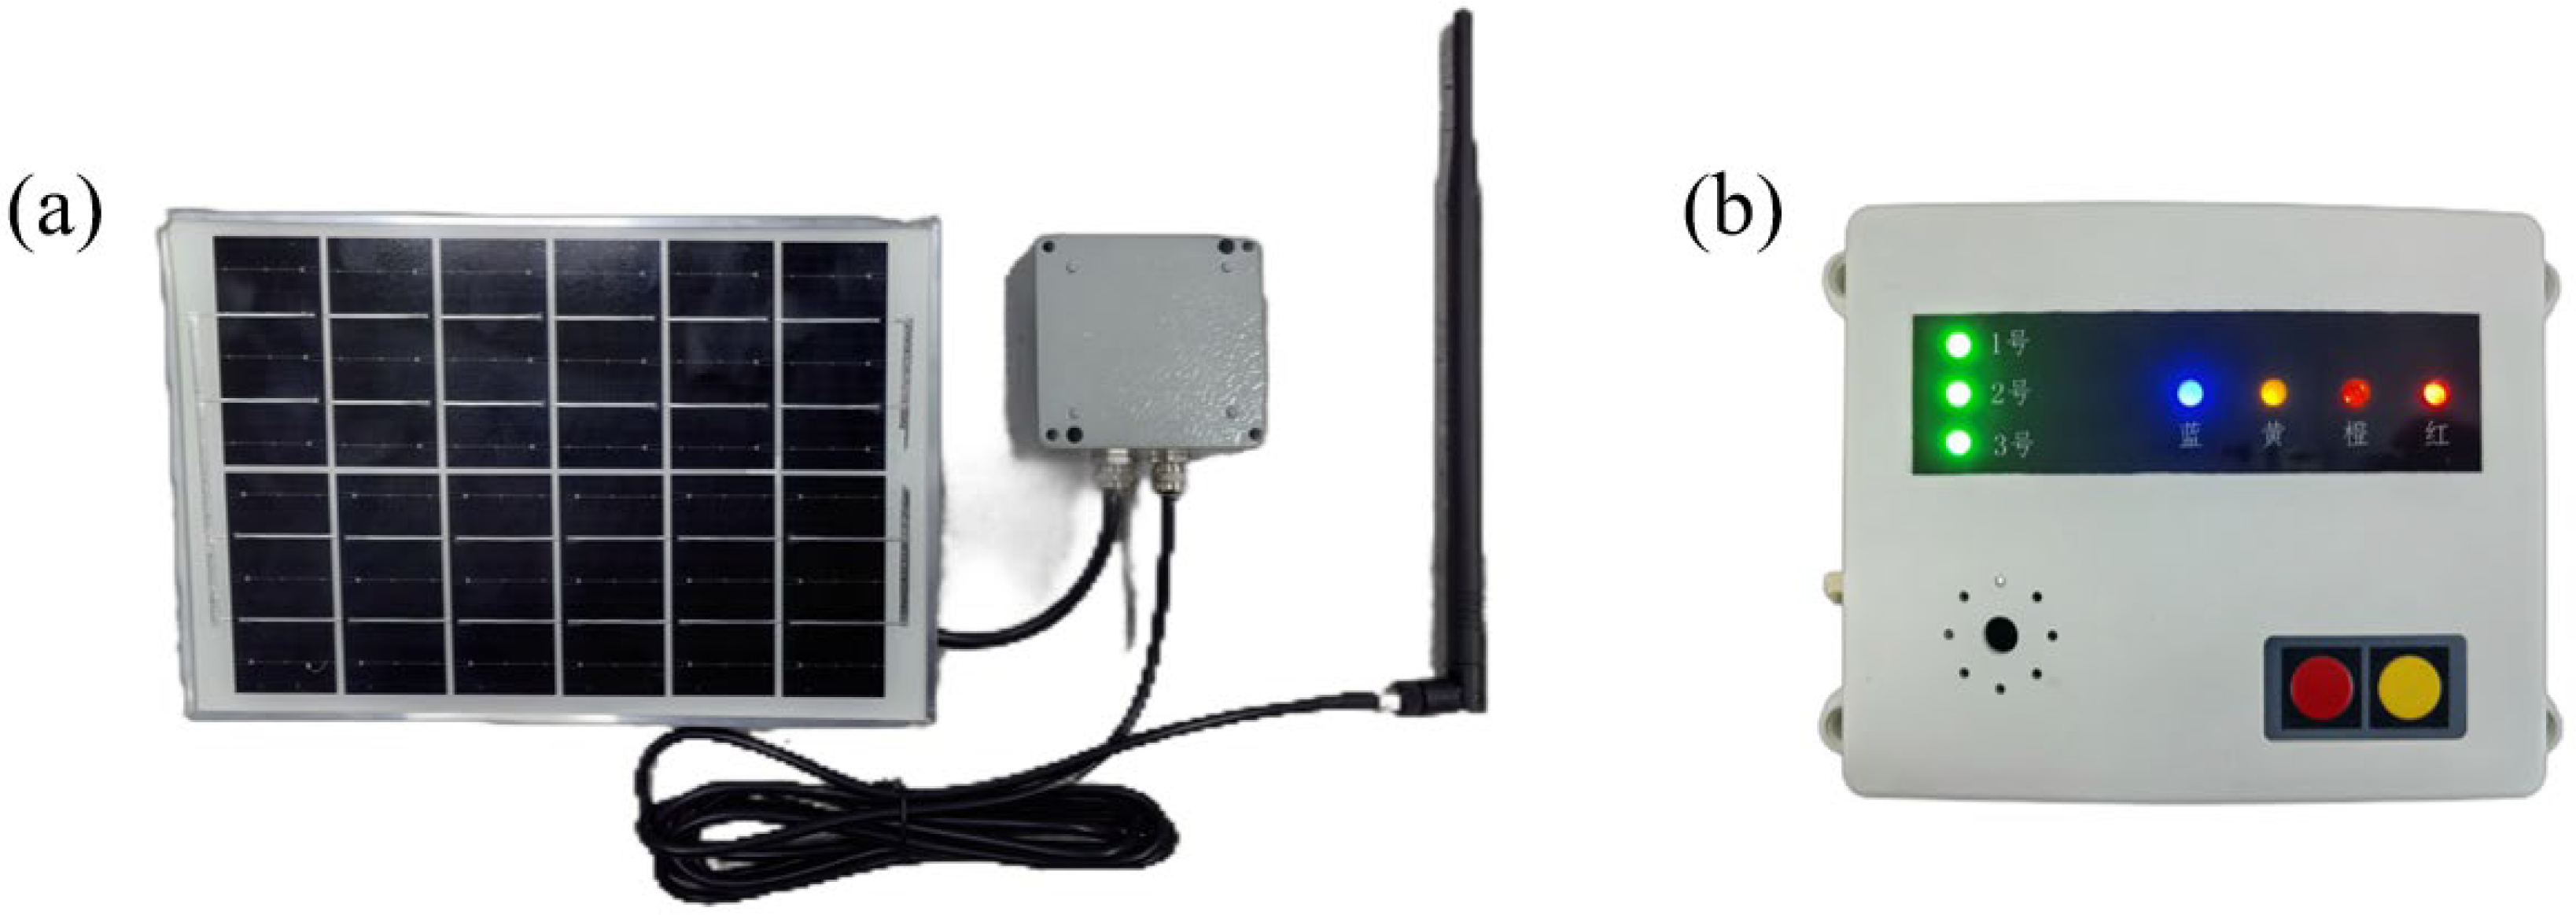
The system consists of a monitoring node and an independent alarm unit, linked wirelessly over distances of up to 5 km (Figure 1). With edge-computing capabilities, it functions autonomously without external network support.
Figure 1.
Product components: (a) Micro-seismic Monitoring Unit; (b) Micro-seismic Alarm Unit.
The two units are deployed in distinct roles to facilitate community-based early warning. The micro-vibration monitoring unit can be installed underground, fixed on slope surfaces, or mounted on structural elements. Conversely, the alarm unit is designed for direct community access; it is typically installed within residents’ homes or community centers (supporting wall-mounting or pole installations), serving as their personal warning interface. In terms of power consumption, the monitoring device operates at ≤20 mW under normal conditions, uses replaceable batteries, and can be supplemented by solar panels. The alarm unit consumes ≤2 W and adopts a dual-power configuration combining batteries with solar supply, ensuring continuous operation even where mains electricity is unavailable.
The devices exhibit strong environmental adaptability, functioning within −20 °C to 70 °C. The monitoring unit operates reliably under humidity levels of 0–98 HR, and the alarm unit under 0–90 HR. For communications, the monitoring unit integrates LoRa and 4G connectivity, while the alarm unit further supports public-network access combined with a LoRa self-organized network, maintaining stable performance even during emergency conditions. This design ensures a direct technology transfer to the community: residents are not required to operate complex monitoring equipment but can respond autonomously based on clear visual or auditory alerts from the alarm unit upon receiving signals from the professional monitoring node.
This spatial separation is a critical design feature for effective early warning. The monitoring unit is installed directly on the potential landslide body (e.g., the upper slope or scarp area) to detect the onset of accelerating instability, while the alarm unit is placed within the community or infrastructure to be protected. This configuration creates a crucial time buffer for evacuation. Upon detecting precursory acceleration signals, the monitoring unit immediately triggers the alarm unit via the LoRa link. Residents can thus respond to clear visual/auditory alerts before the sliding mass propagates from the monitoring point to the community area, leveraging the physical delay in landslide movement.
2.2. Working Principle
The monitoring unit employs custom-built triaxial MEMS accelerometers to continuously record high-frequency acceleration signals of the slope mass along the X, Y, and Z axes at 100–1000 Hz, achieving a precision of ±0.5 mg. Edge-side processing employs a two-stage denoising strategy to minimize ambient noise. First, wavelet threshold filtering is applied using the ‘sym8’ (Symlets) basis, chosen for its effectiveness in capturing transient features. A hybrid thresholding rule combines Stein’s Unbiased Risk Estimate (SURE) criterion with a fixed noise-level-dependent limit, followed by soft-thresholding to preserve signal smoothness. Subsequently, a Kalman filter is implemented primarily to mitigate the integration drift inherent in deriving displacement from acceleration. The filter is designed with a state vector encompassing position and velocity, utilizing a constant-velocity state transition model between high-frequency samples. Its process and measurement noise parameters are calibrated using data from a stable post-installation period. By fusing the preliminarily integrated velocity with this dynamic model, the filter outputs optimized, drift-corrected estimates of velocity and displacement, which are then used for all downstream analysis.
Through this multi-parameter fusion approach focusing on the corrected displacement, tilt, and vibration, the system characterizes landslide motion from complementary temporal and spectral perspectives [25]. Tilt is determined by the spatial decomposition of the static gravity components from the triaxial accelerometer. Vibration analysis is performed by extracting frequency-domain energy features through Fourier transform and wavelet packet decomposition to identify precursors. Finally, the processed data are transmitted to the early-warning terminal in real time via dual-mode 4G/LoRa communication. All algorithms operate collaboratively within the edge-computing module, forming a streamlined processing chain.
2.2.1. Displacement Calculation
Displacement calculation is performed using a time-domain integration method, in which acceleration signals are converted into displacement through double integration [26]. Prior to integration, the raw acceleration data are preprocessed, and noise is removed using Kalman filtering [27,28]. Since the output of the acceleration sensor is a discrete time-series signal, continuous integration cannot be performed directly to obtain velocity or displacement. Therefore, numerical integration methods must be adopted to achieve an approximate solution. In numerical analysis, compared with the simple rectangular integration method, applying the trapezoidal integration method can more effectively reduce cumulative errors during the integration process. The filtered acceleration data are first integrated to obtain velocity (Equation (1)) and then integrated a second time to derive displacement (Equation (2)).
where represents the acceleration output at time step n; represents the velocity at time step n; represents the displacement at time step n.
Based on the above equations, once the initial velocity of the monitored soil mass is determined, the real-time displacement of the target object can be obtained from the real-time acceleration output of the MEMS sensors.
2.2.2. Tilt Calculation
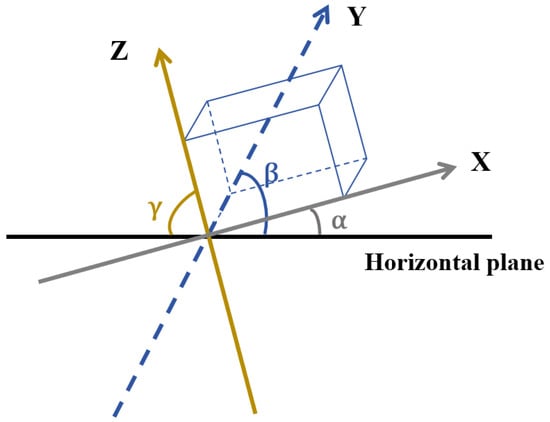
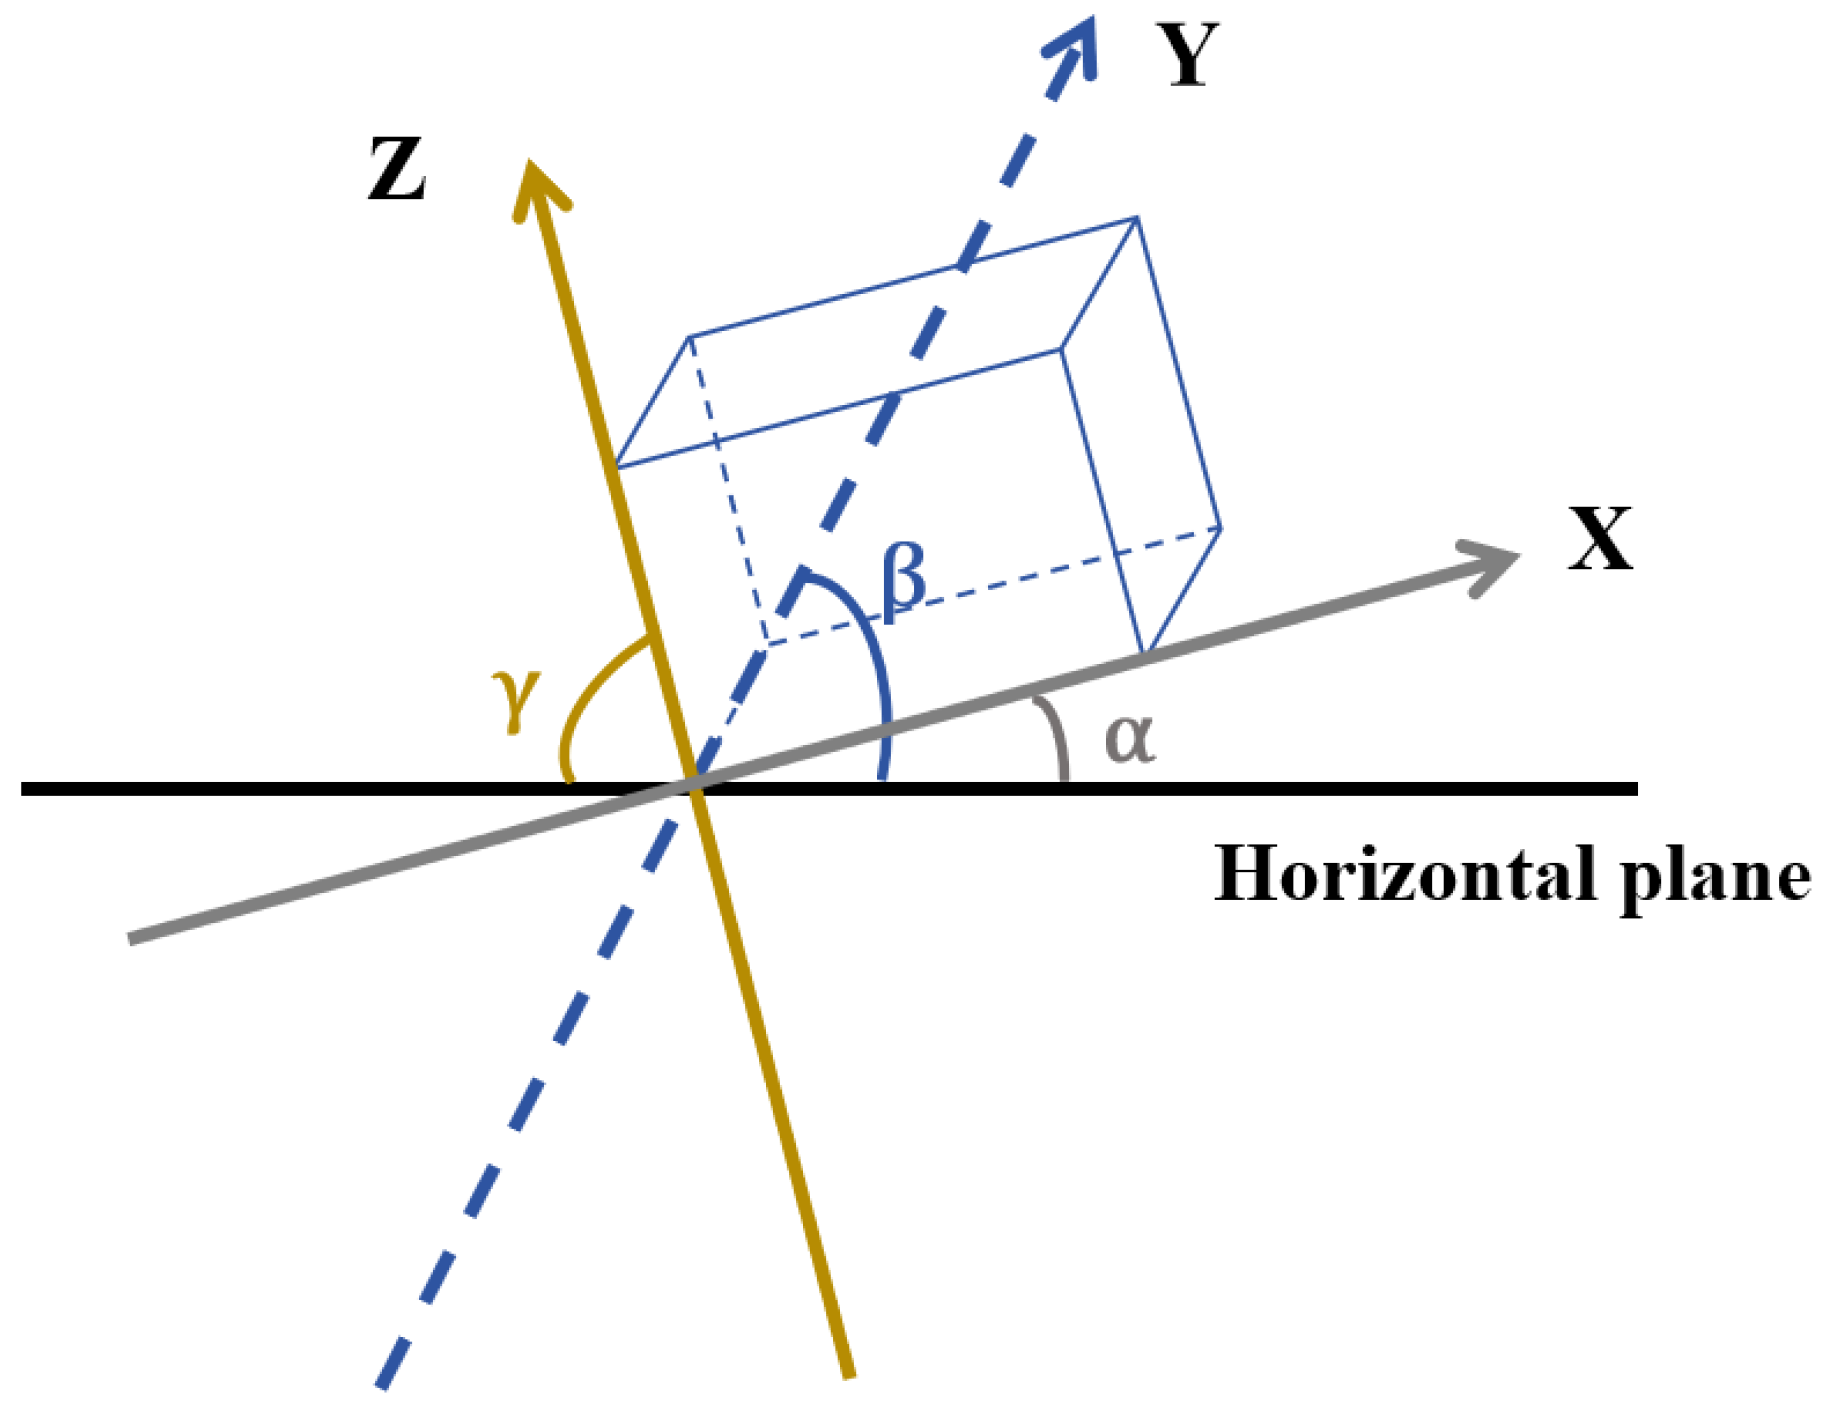
When the sensor is in a static or quasi-static state, the primary component detected along its sensitive axes is the gravitational acceleration. Based on this characteristic, the core concept of tilt calculation is to perform spatial decomposition of the gravity acceleration vector obtained from the triaxial accelerometer (typically denoted as the X, Y, and Z axes) (Figure 2). Assuming that there is a relative rotation between the sensor’s local coordinate system and the reference coordinate system (the local horizontal coordinate system), the tilt angles of the sensor axes relative to the horizontal plane can be calculated by measuring the gravitational acceleration components along the three sensitive axes of the sensor (Ax, Ay, Az) [29].
Figure 2.
Schematic diagram of triaxial inclination.
Specifically, the tilt angle of a given axis relative to the horizontal plane can be obtained by calculating the arctangent of the ratio between the acceleration component along that axis and the magnitude of the projection of gravitational acceleration onto the plane formed by the other two axes.
The angle α between the X-axis and the horizontal plane is calculated as:
The angle β between the Y-axis and the horizontal plane is calculated as:
The angle γ between the Z-axis and the direction of gravitational acceleration is calculated as:
2.3. Data Characteristics
The monitoring data generated by the system exhibit four key characteristics: high frequency, multidimensional parameters, low redundancy, and strong resistance to interference. The high sampling rate enables the capture of transient events at the millisecond scale, allowing the full evolution of slope instability, from slow deformation to rapid failure to be recorded. The dataset integrates multiple parameters, including triaxial acceleration, displacement, tilt, and vibration spectra, with synchronized computation and correlation analysis conducted through edge processing. To minimize data redundancy, only statistical features are stored during normal operation, whereas full waveform records and detailed spectral information are triggered when anomalies are detected. A hybrid denoising strategy that combines Kalman filtering with wavelet packet decomposition effectively suppresses environmental disturbances (e.g., wind and rainfall effects or machinery vibrations), ensuring reliable monitoring performance in complex terrains. Data transmission employs an adaptive 4G/LoRa dual-mode approach: routine data are uploaded periodically, while abnormal conditions trigger real-time alerts, balancing low-power operation with high timeliness.
3. Early Warning Method
3.1. Early-Warning Decision Method for a Single Device Using Motion Intensity and Variation Rate
The single-device early warning method proposed in this study aims to achieve graded early warning by quantifying the motion intensity of the landslide body and its dynamic variation rate, in combination with predefined thresholds. The core of this method lies in defining and calculating a comprehensive landslide motion intensity factor (y) and further analyzing its instantaneous variation rate (y′).
3.1.1. Data Acquisition and Anomaly Detection
The acceleration data are acquired in real time by the MEMS sensors deployed in the target area. To focus on potential landslide motion signals, a well-defined anomaly detection procedure is first executed. Upon installation, the system enters a dedicated learning period (typically 24–72 h). During this phase, it operates in a monitoring mode without issuing warnings, collecting acceleration data to establish the site-specific ambient noise characteristics. For each axis, the mean () and standard deviation () of the pre-processed (denoised) acceleration are calculated. After the learning phase, the system switches to the active warning mode. An “anomalous event” is formally defined and triggered when the absolute value of the pre-processed acceleration on any sensing axis exceeds a threshold of for one or more consecutive sampling points. Here, N is a tunable parameter (typically ranging from 2.5 to 4) that balances detection sensitivity and the false alarm rate, and is set according to site conditions, sensitivity requirements, and hazard type. For the model test described in this study, N was set to 3. Once an anomalous event is triggered, a data packet is generated containing: the sensor ID, the timestamp of the first sample that crossed the threshold (which marks the onset time of the event), and the peak filtered acceleration value within that event sequence. This packet is transmitted to the central processing unit as the fundamental input for subsequent intensity calculation and warning analysis.
3.1.2. Landslide Motion Intensity Factor ()
The early warning control terminal calculates the motion intensity factor y based on the received anomalous data. The severity of landslide motion is jointly determined by the amplitude of acceleration and the frequency of anomalous events. To comprehensively characterize this intensity, we define the landslide motion intensity factor y as (Equation (6)):
where denotes the current anomalous acceleration value, , , represent the occurrence times of the current, previous, and second previous anomalous events, respectively; and is a dimensionless adjustment constant (default value of 1) used to balance dimensional consistency and sensitivity.
The rationale behind this formula is that directly reflects the instantaneous amplitude intensity of the motion, the denominator represents the minimum time interval between the two most recent anomalous events, and its reciprocal approximates the instantaneous frequency of anomaly occurrence. A shorter time interval (i.e., a higher frequency) results in a larger value, indicating that the motion may be more active or accelerating. Therefore, a larger y value indicates a more intense current landslide motion state.
3.1.3. Variation Rate of Motion Intensity ()
The hazardous potential of a landslide depends not only on its current motion intensity but, more importantly, on its acceleration trend. To capture the dynamic variation in the motion intensity factor, we model its short-term temporal behavior. A sequence of the most recent m continuously calculated y values (with m determined based on the required response speed and trend stability) is selected and locally fitted using a fourth-order polynomial (Equation (7)):
where all polynomial coefficients are obtained through the fitting process and treated as known parameters.
The fourth-order polynomial is chosen to balance model flexibility and the risk of overfitting, allowing the nonlinear variation patterns of y within a short time window to be effectively captured. By taking the first derivative of the fitted curve y (t) with respect to time t, the instantaneous variation rate of the motion intensity y′ is obtained (Equation (8)):
directly reflectsdirectly reflects the rate of change in the motion intensity factor at each time step. A larger absolute value of typically indicates a higher risk of drastic changes in the motion state.
3.1.4. Early Warning Level Determination
The early warning level is determined based on the landslide motion intensity factor y and the absolute value of its variation rate |y′| (the absolute value is used to account for the risk of rapid re-acceleration after deceleration), in combination with predefined thresholds [y] and [y′]. A two-dimensional decision matrix is adopted, in which the ranges of y and |y′| relative to their respective thresholds [y] and [y′] are mapped to different early warning levels (Table 1).
Table 1.
Single-device early warning level decision matrix.
3.2. Multi-Device Collaborative Early Warning Method Based on Spatial Anomaly Fusion
To enhance the spatial coverage and reliability of landslide early warning, a collaborative early warning framework is constructed based on multiple distributed MEMS sensors. The core of this method lies in fusing spatially distributed anomaly information, quantifying the overall activity frequency, motion intensity, and distribution of anomalous sensor nodes, and ultimately calculating a comprehensive landslide risk index to trigger the corresponding early warning level.
To evaluate the overall instability risk of the landslide, the anomaly levels from all sensor nodes are integrated, and the comprehensive landslide risk index F is defined as follows (Equation (9)):
where represent the numbers of monitoring devices assigned to Early Warning Levels I, II, III, and IV, respectively.
When all monitoring devices are assigned to Early Warning Level I, the value of F is 1. When all devices are at Level II, the comprehensive landslide risk index F is 0.8. When all devices are at Level III, F becomes 0.6, and when all devices are at Level IV, F is 0. Based on this rule, 0.8, 0.6, and 0.4 are set as the thresholds for multi-device early warning determination (Table 2). The final early warning level is then output according to the calculated risk index F.
Table 2.
Multi-device early warning level decision matrix.
4. Applications
A large-scale outdoor landslide experimental site was constructed in Yunwu Mountain, Da’an Town, Yongchuan District. By inducing large-scale landslide instability in the physical model, monitoring data covering the full deformation–failure process were obtained using GeoMAS to verify its monitoring and early warning performance. Here, the full process refers to the continuum of slope responses captured by high-frequency MEMS sensors, encompassing the initial subtle changes in vibration energy and tilt (quantified by the motion intensity factor y), through the phase of accelerating deformation marked by increasing event frequency, up to the final catastrophic sliding event. This provides a complete kinematic record of the failure evolution, complementing visual observations.
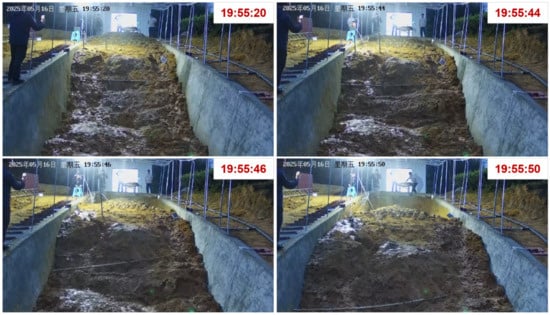
The experimental site mainly consists of a landslide testing flume and a data acquisition and analysis room. The testing flume is approximately 20 m in length, with an inverted trapezoidal cross-section (5 m in top width and 3.5 m in bottom width) and a sliding surface inclination of about 17°. Subsurface seepage pipes are installed horizontally at 2 m intervals along the flume bottom to simulate groundwater infiltration and the resulting deterioration of the mechanical properties of the rock–soil materials along the sliding surface. A rainfall system is installed horizontally at 0.5 m intervals above the slope surface, allowing dynamic adjustment of both rainfall intensity and spatial distribution. This setup enables simulation of landslide failure processes under multiple rainfall conditions. The model parameters and a field photograph of the experimental setup are shown in Figure 3.
Figure 3.
Landslide Experimental Site.
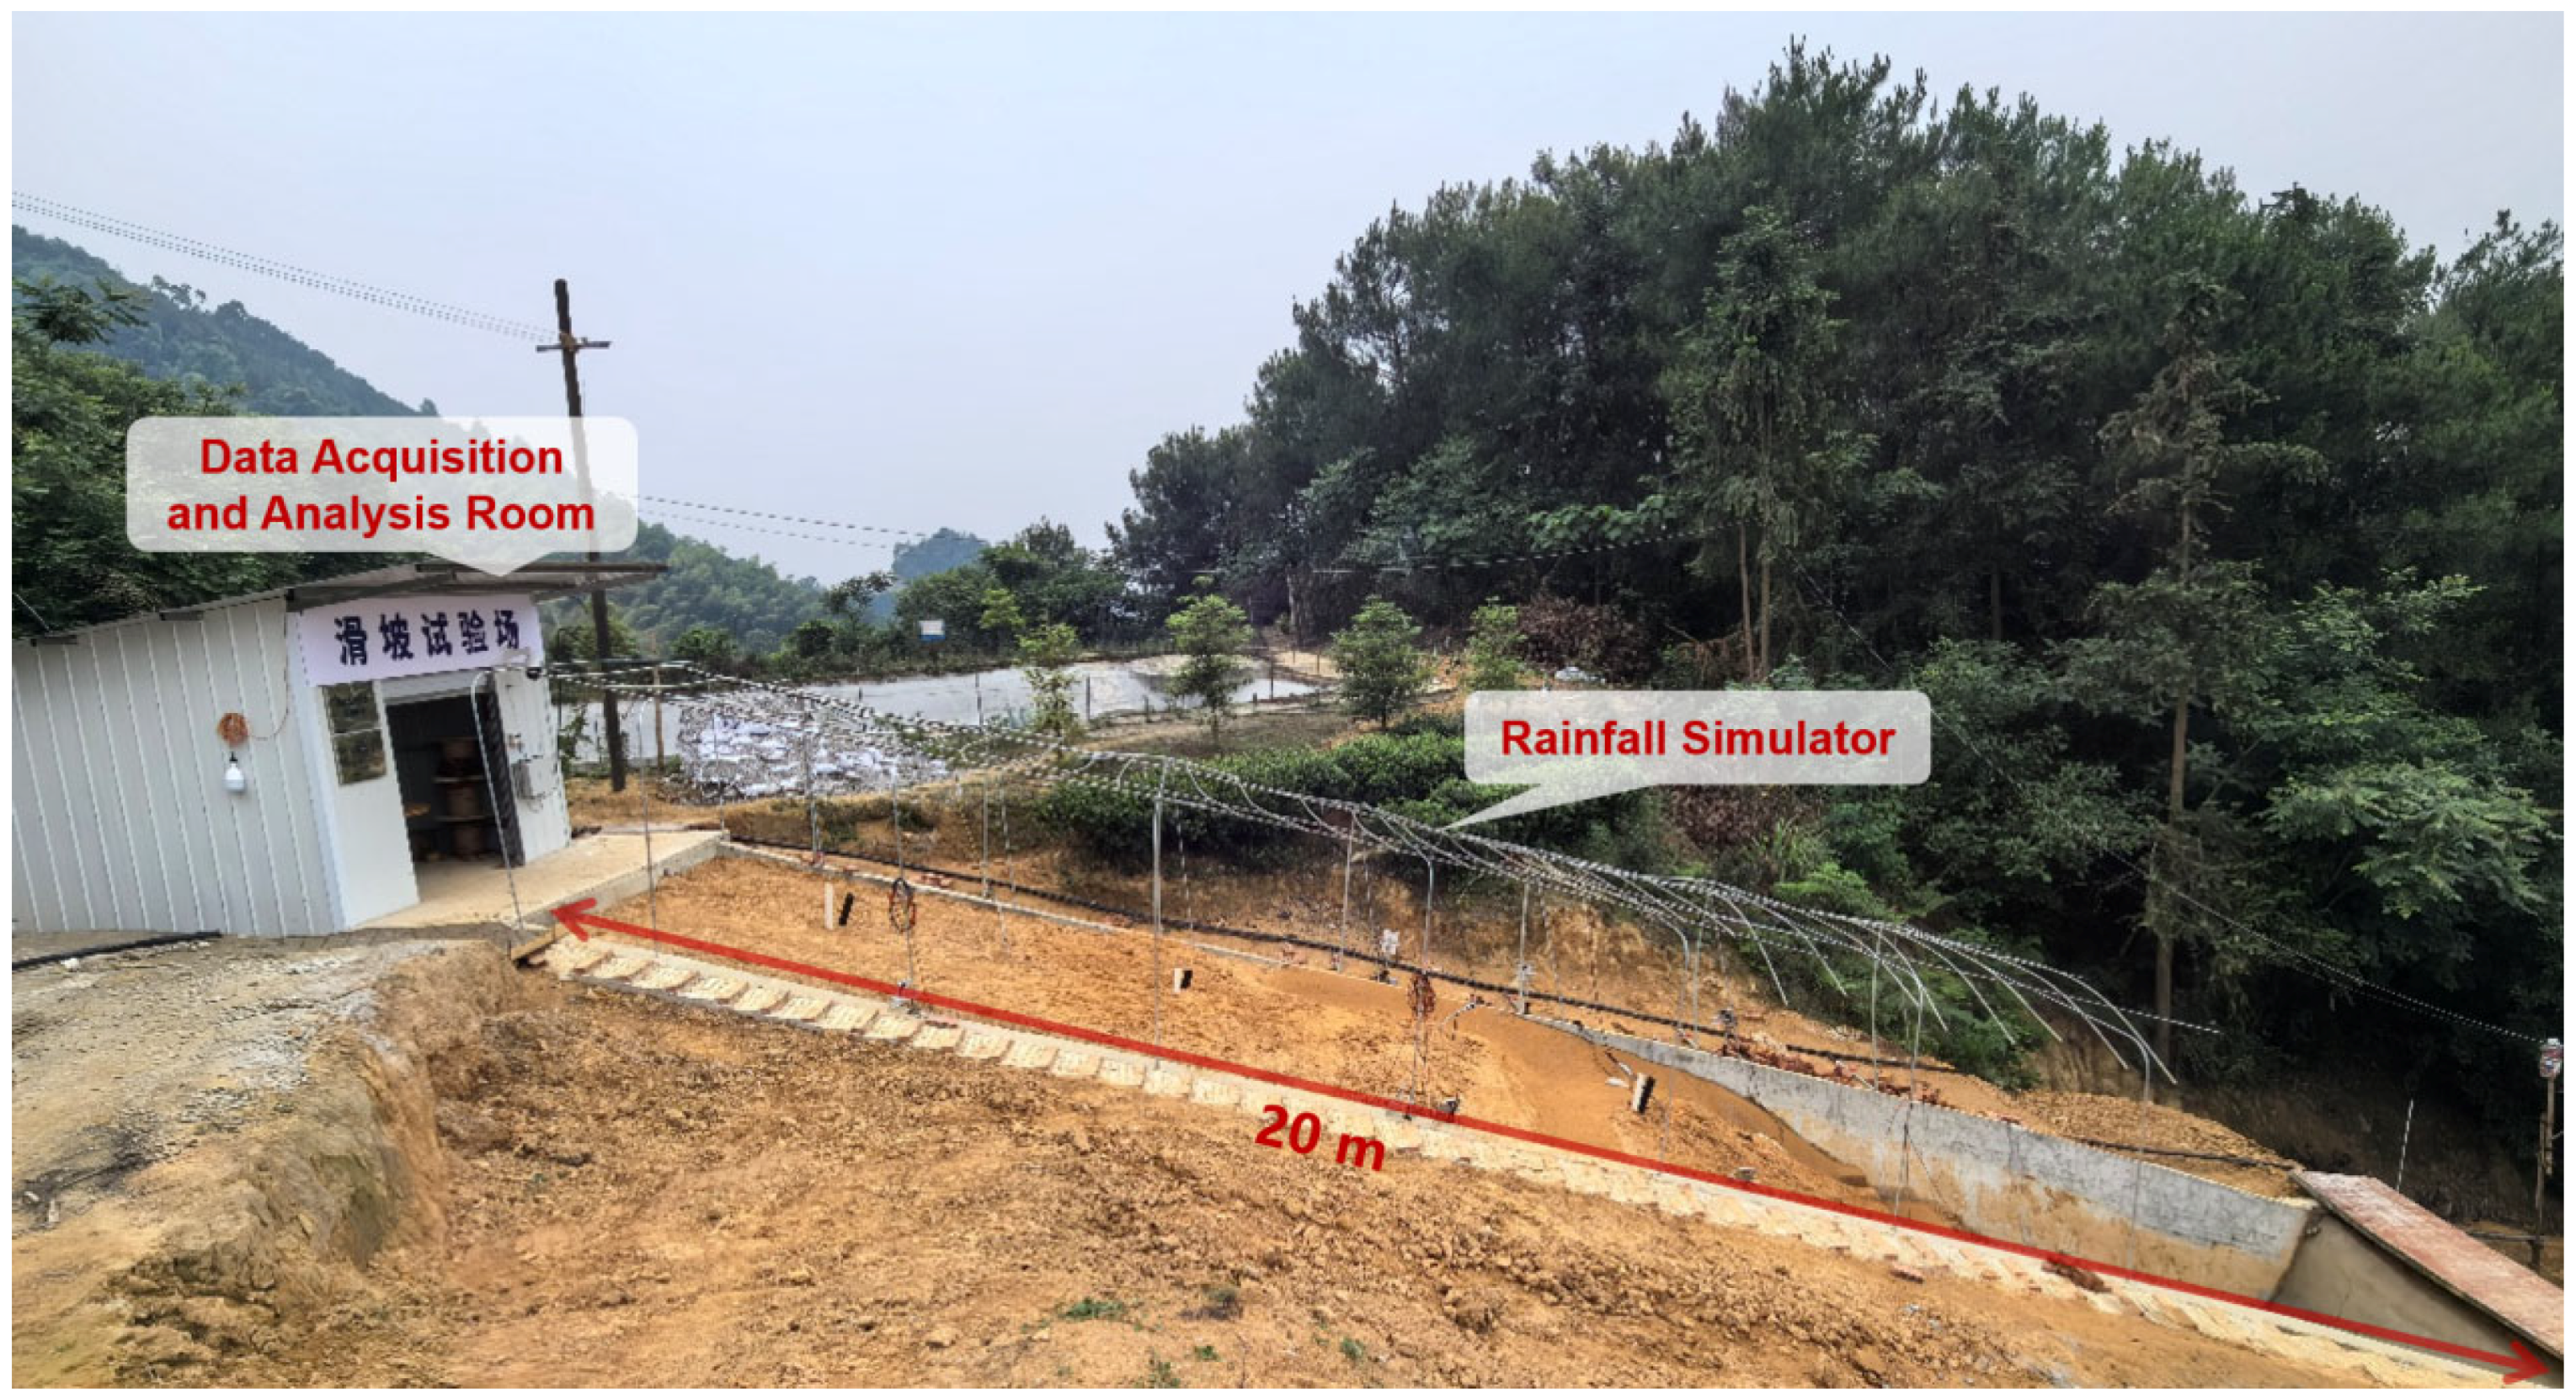
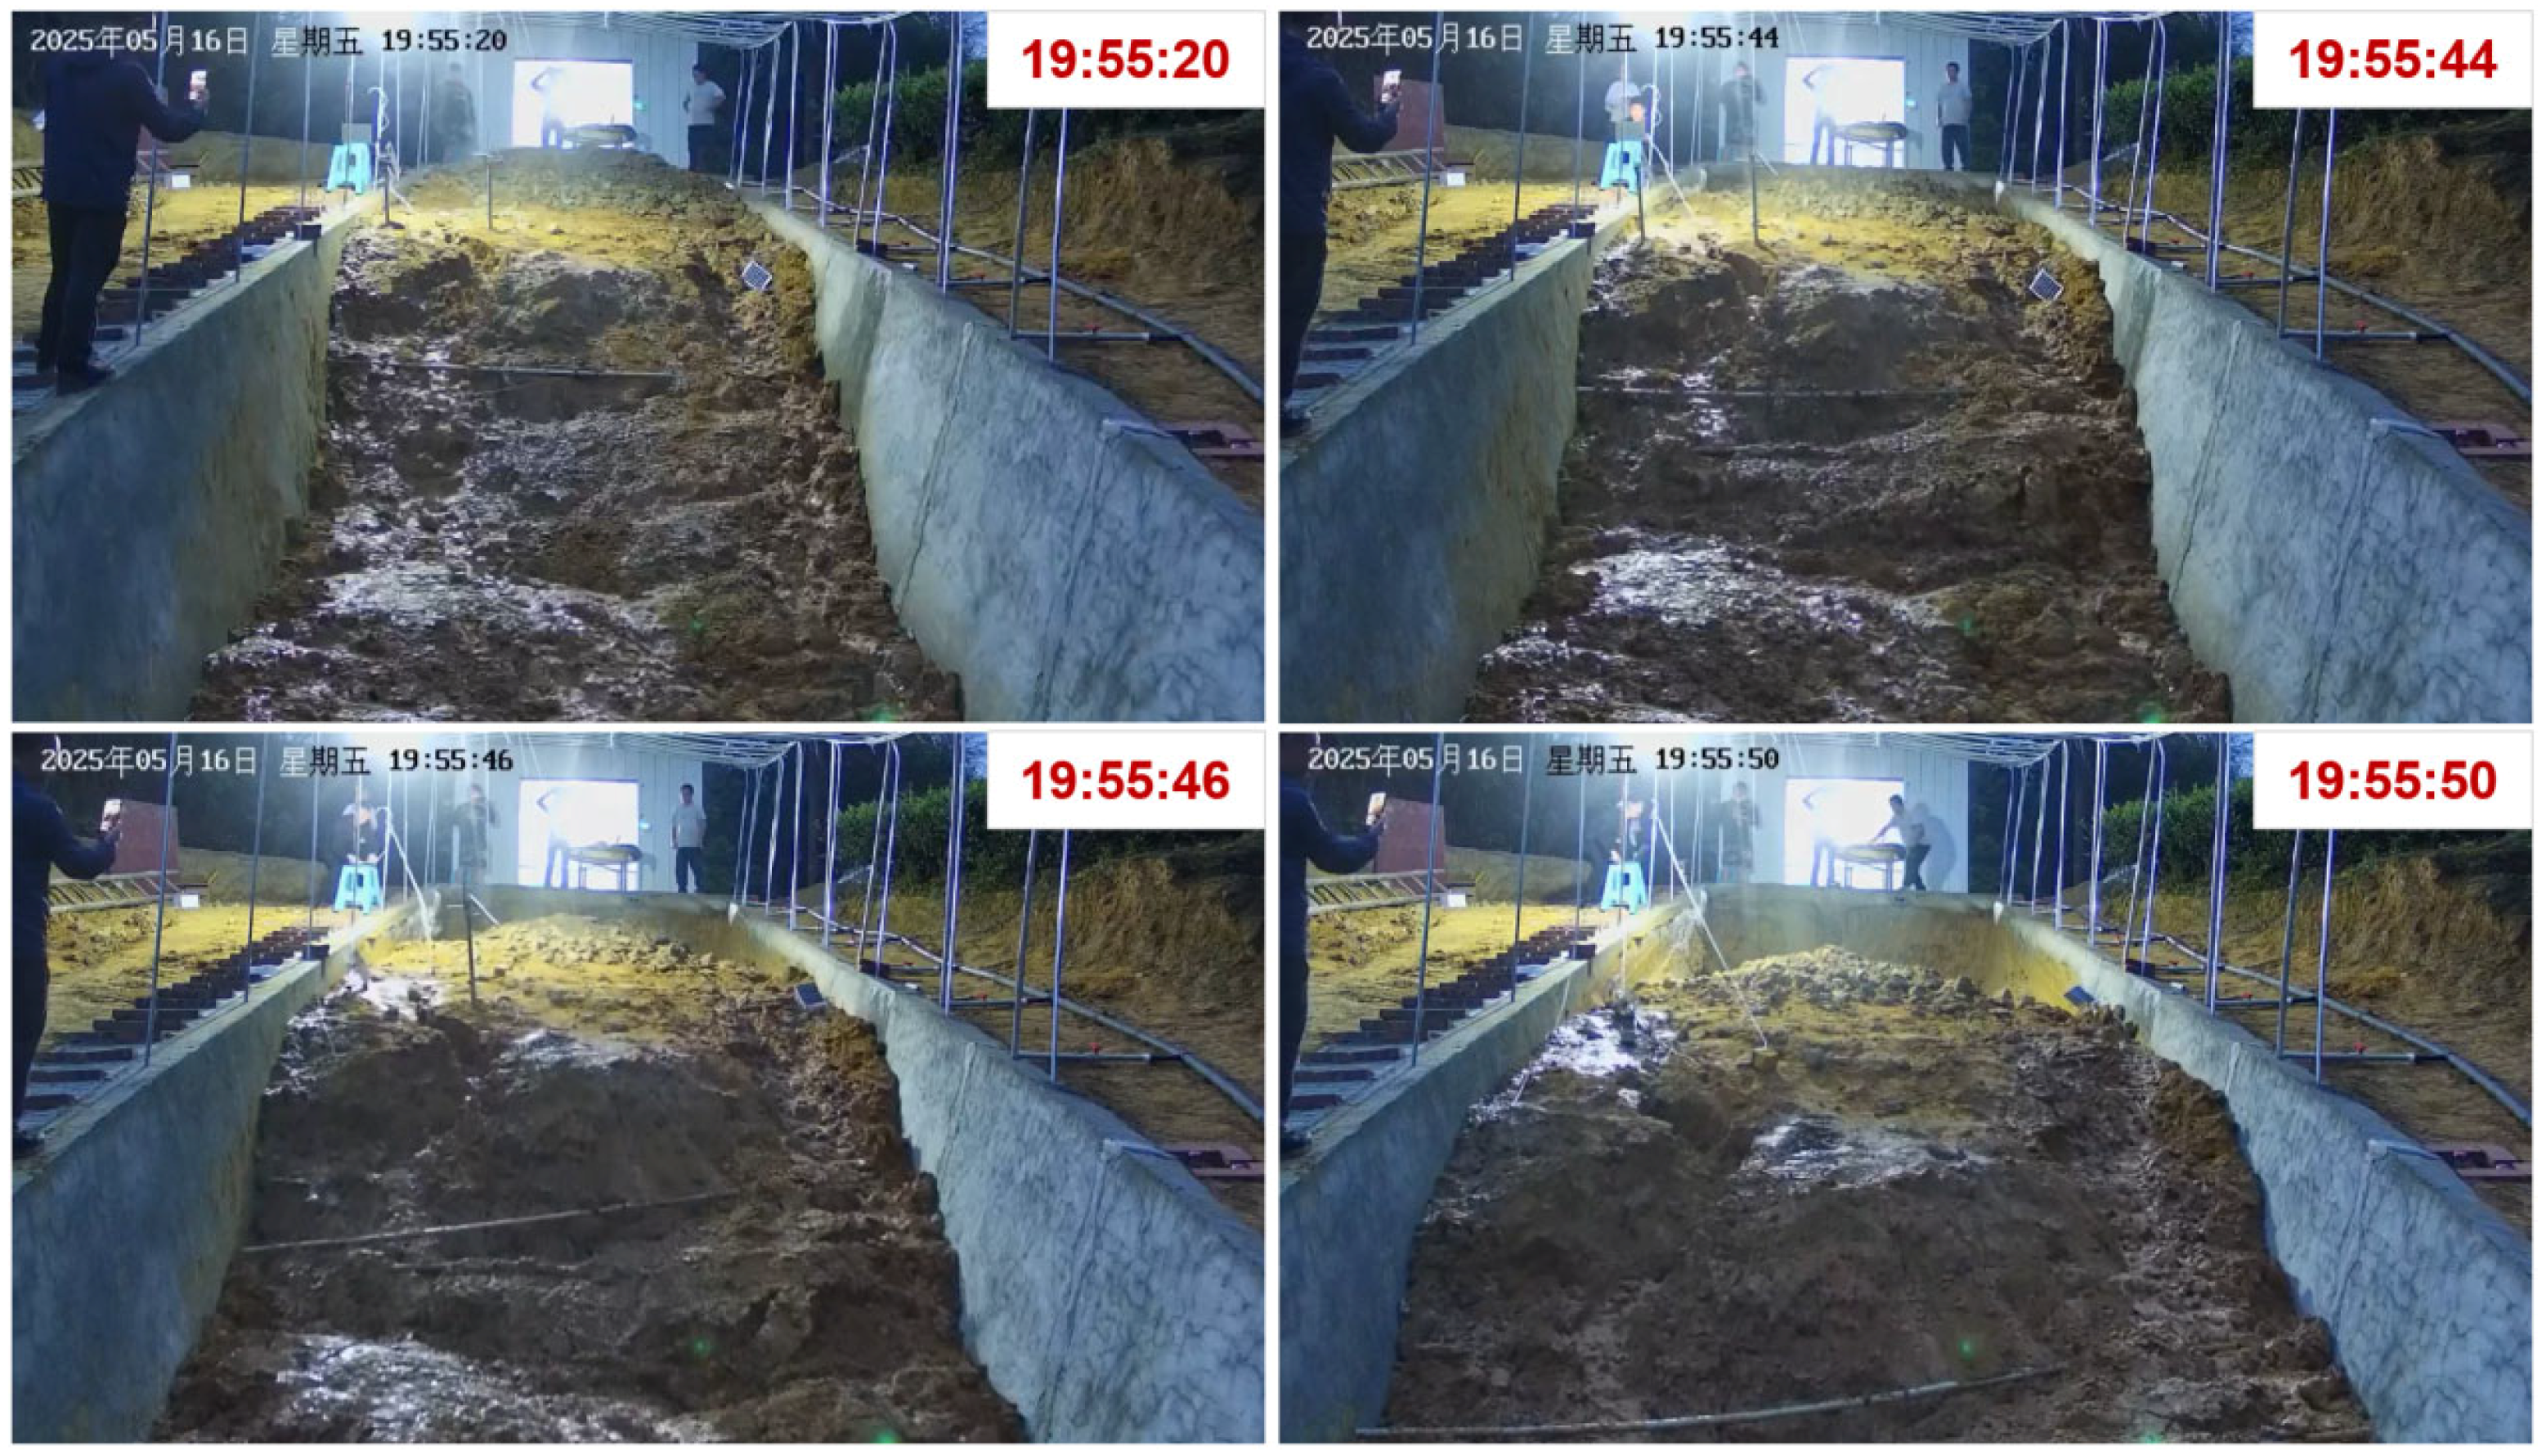
On 16 May 2025, a complete process of slope evolution from stability to failure was successfully simulated and observed through controlled artificial rainfall experiments. Video recordings of the entire experiment (Figure 4) clearly revealed the key stages of landslide evolution. During the initial phase of the experiment, the slope remained generally stable under rainfall infiltration. At around 19:55:20, minor wetting-induced deformation and localized surface creep were detected, while no visible cracking appeared representing a typical phase of deformation accumulation. A marked behavioral shift occurred at 19:55:40, when the slope entered a transition stage. Over the next six seconds (until 19:55:46), a prominent tensile crack rapidly propagated along the rear edge, implying the breakthrough of a potential sliding surface and signaling that the slope had reached a near-critical instability condition. Ultimately, rapid and large-scale sliding was triggered at 19:55:50. The recorded evolution clearly illustrates the full progressive process of landslide failure, from initiation and acceleration to catastrophic collapse.
Figure 4.
Landslide deformation–failure process.
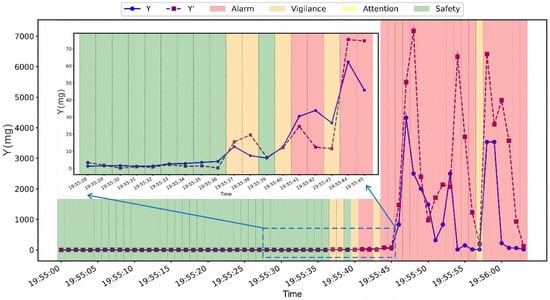
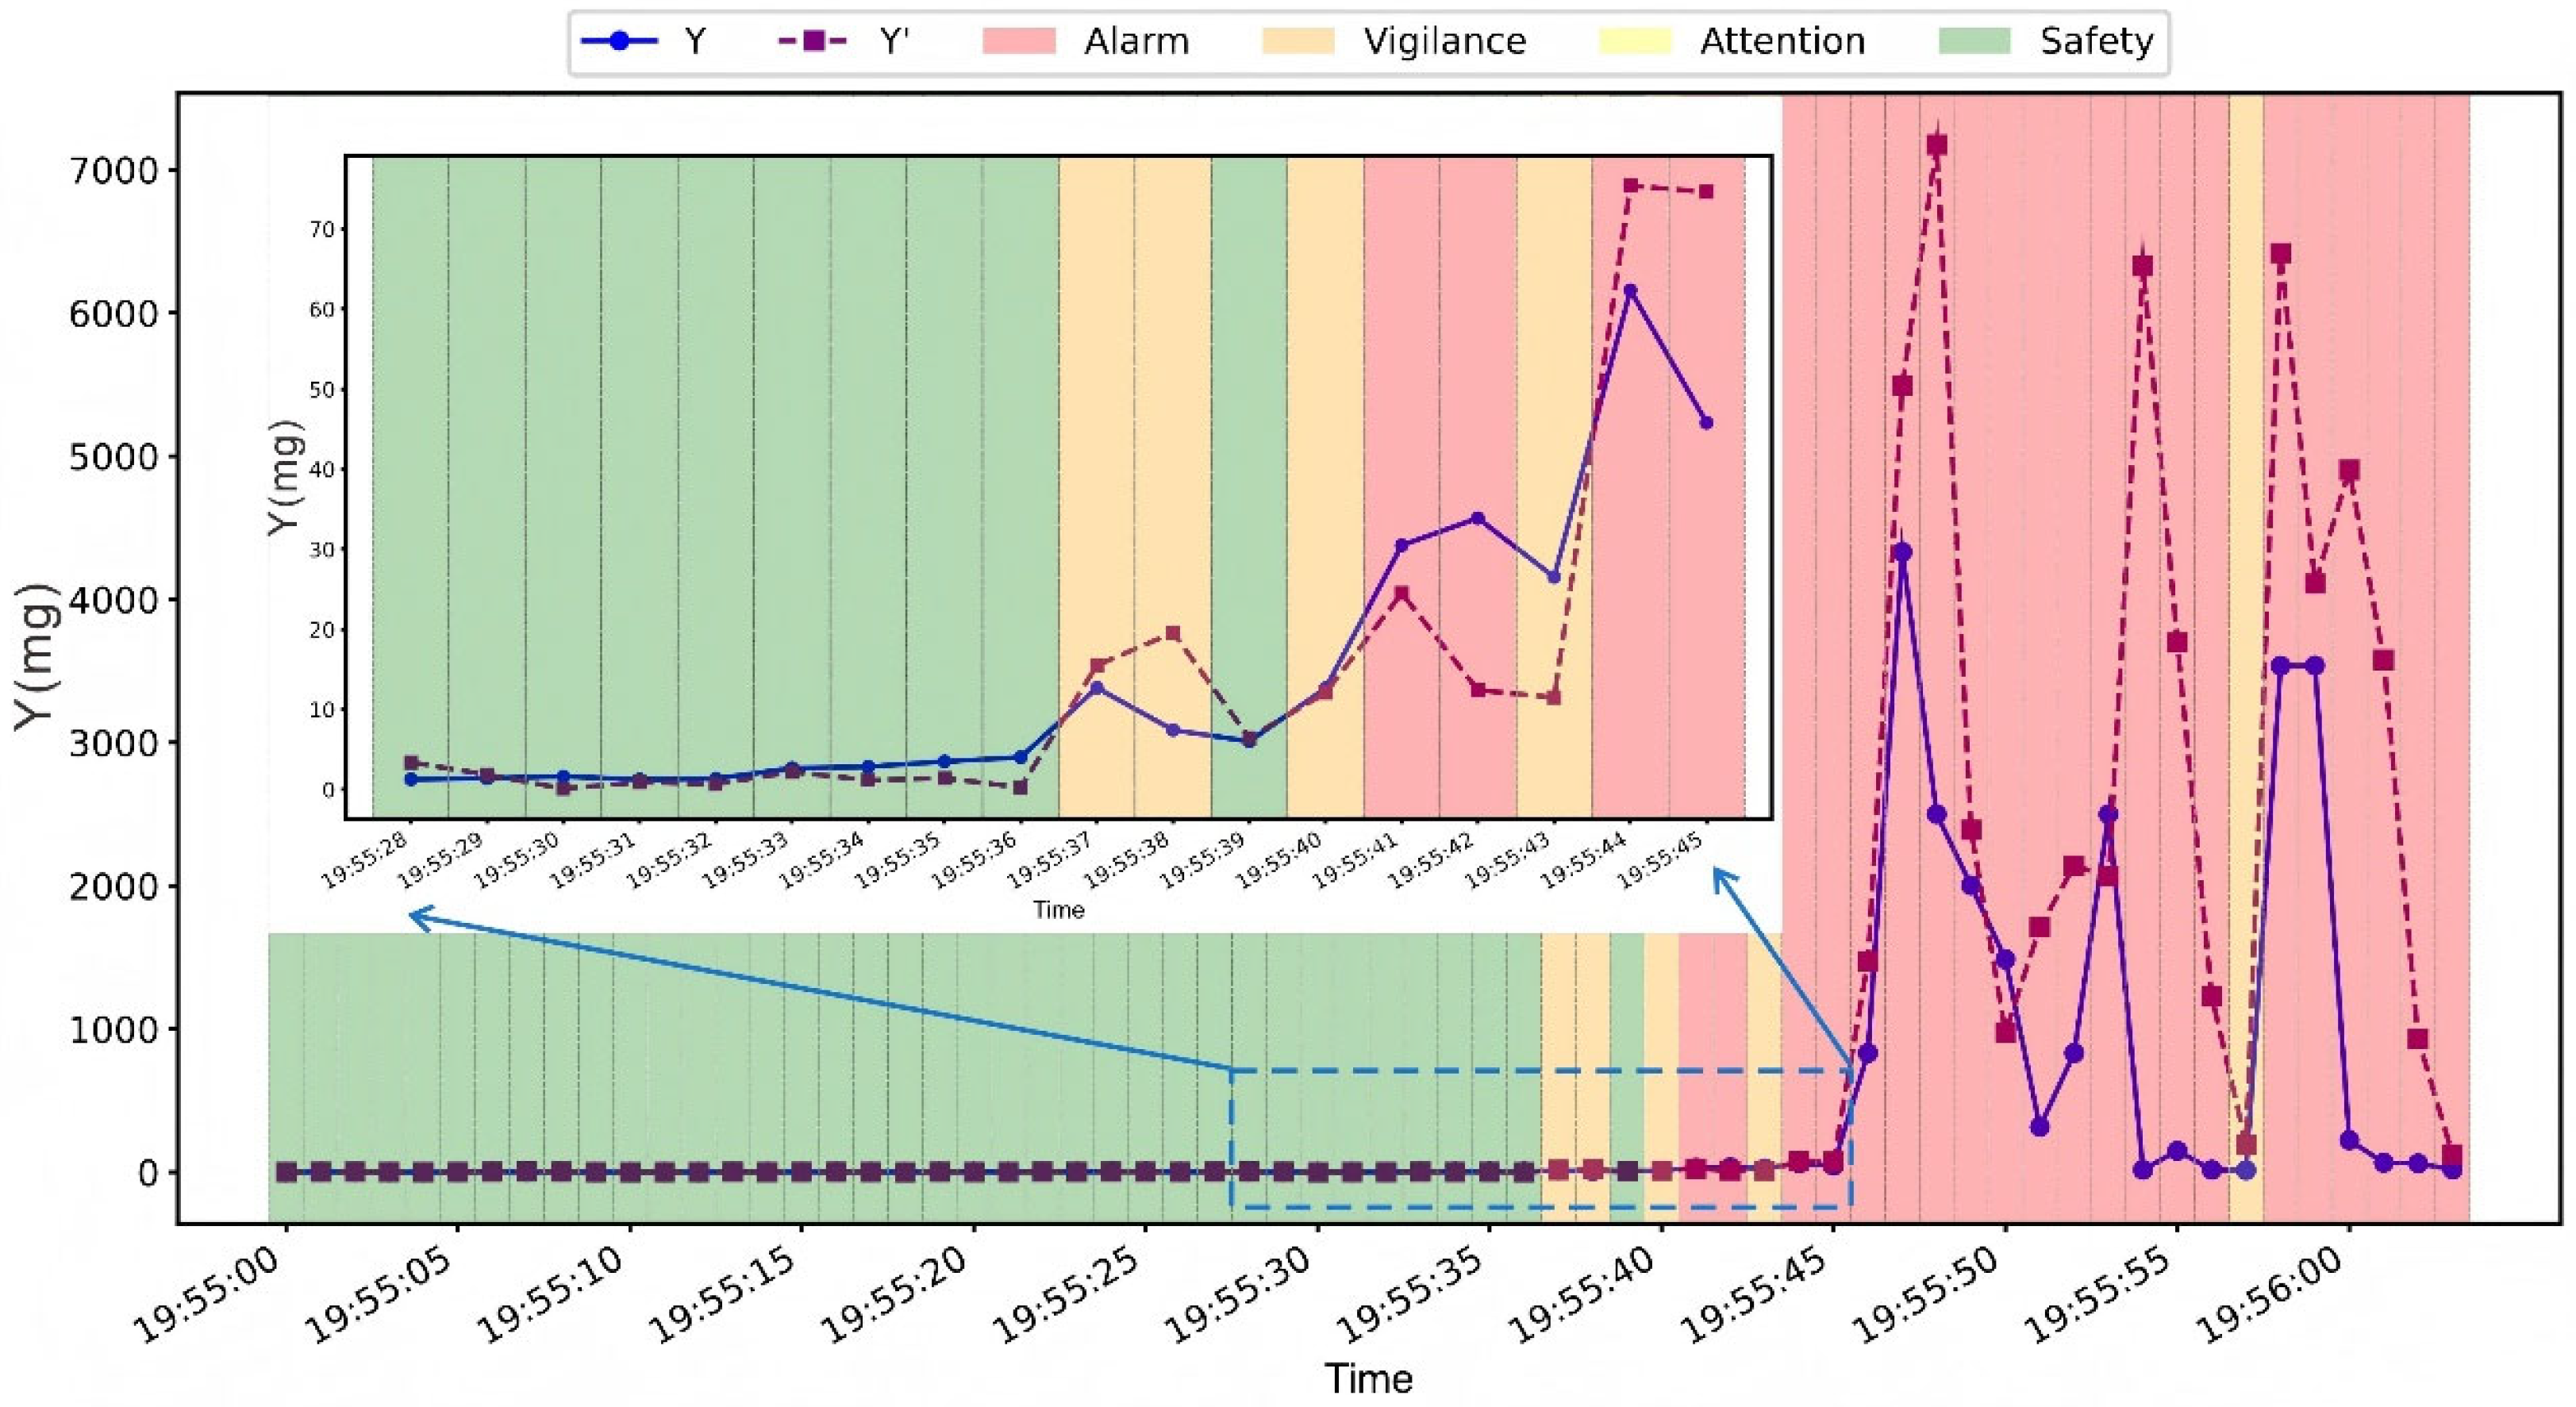
The GeoMAS system successfully recorded the continuous dynamic response of the slope throughout the experiment. Based on prior long term measurements of ambient vibration, two core threshold indicators were established within the early-warning algorithm: the motion-intensity factor (y), reflecting instantaneous disturbance magnitude, was set to 20 mg, and its rate of change (y′), indicating the trend of accelerating deformation, was set to 15. Real-time early-warning levels were then determined using this dual-indicator framework, as defined in Table 1 (Figure 5). The results indicate that the system maintained a “Safe” status before 19:55:36, consistent with the stable condition of the slope. At 19:55:37, y exceeded its threshold for the first time, and the warning level promptly upgraded to “Vigilance”, even though no visible cracks had formed, highlighting the system’s sensitivity to early precursors. Subsequently, at 19:55:41, concurrent with the emergence of a tensile crack along the rear edge, the system elevated the warning to the highest level, “Alarm”. This status persisted until the slope underwent rapid failure at 19:55:50, demonstrating effective advance warning of the imminent collapse.
Figure 5.
Early warning time series derived from GeoMAS.
In summary, the GeoMAS system provided a 13 s system response time from the detection of precursory signals at the monitoring unit (installed on the slope) to the issuance of an alarm at the remote alarm unit in this experiment. The warning level progressed from “Safe” to “Vigilance” upon initial threshold exceedance and was elevated to the highest “Alert” level concurrent with visible crack formation, demonstrating the system’s ability to track deformation acceleration and its sensitivity to precursors. These results verify the robustness and responsiveness of the dual-threshold strategy and the associated algorithm. Critically, in a real-world deployment, this configuration creates a substantially longer effective evacuation window. The monitoring unit acts as an upstream sentinel, triggering the alarm before the landslide mass reaches the residential area where the alarm unit is located. The dominant component of the evacuation window is, therefore, the additional travel time required for the landslide to propagate from the instrumented slope section to the community, a direct result of the spatial separation between the two units. This demonstrates the system’s practical design for generating actionable lead time based on the detection of dynamic precursors at a strategic location.
5. Discussion
The MEMS-based high-frequency landslide monitoring device and real-time warning methodology developed in this study exhibit considerable promise for disaster prevention and mitigation, benefiting from both theoretical advances and technological integration. The novelty of this work is anchored in the synergistic integration of three key aspects: (1) a hardware–software co-design that embeds a novel early-warning algorithm into the edge-computing unit, enabling not only high-sensitivity, high-frequency monitoring but also real-time, on-site analysis and decision-making; (2) a community-oriented early-warning architecture that spatially decouples this intelligent sensing node from the alerting unit to maximize actionable lead time; and (3) validation through a controlled, large-scale physical model test capturing the complete failure continuum.
Nevertheless, further work is needed to assess their engineering applicability, technological readiness, and long-term development potential. Accordingly, this discussion addresses four key aspects: comparative device performance, practical advantages, existing technical constraints, and directions for future improvement. By examining current technological bottlenecks alongside real engineering requirements, the system’s application scope is more clearly defined, and pathways for continued enhancement are proposed.
5.1. Performance Comparison with Existing Monitoring Technologies
InSAR technology provides wide-area coverage and millimeter-level deformation monitoring accuracy, making it suitable for large-scale crustal deformation screening [30]. However, its long satellite revisit cycle prevents it from capturing transient features during the acceleration phase of landslides; for example, in the Yongchuan landslide model test, the transition from deformation to failure occurred within only a few minutes. In addition, the test site is located in a vegetation-covered area where significant multipath effects occur, leading to a high probability of monitoring failure in forested terrain. In contrast, MEMS sensors, with high-frequency sampling and second-level response capability, can resolve dynamic changes in acceleration in real time, effectively overcoming the temporal resolution limitations of InSAR.
Unmanned aerial vehicle (UAV) remote sensing performs well in post-disaster emergency surveys and high-precision local modeling due to its flexible deployment and high-resolution radar imaging capabilities [31]. However, its operation is limited by short endurance, weather constraints, and time-consuming data processing. In contrast, MEMS sensors enable real-time early warning through edge computing, support all-weather operation, and feature IP68 protection. Nevertheless, they lack the capability of capturing the spatial geometry of the landslide mass, and thus must be combined with UAV observations to obtain the three-dimensional deformation field of the slope.
GNSS technology estimates ground displacement through satellite signal processing, offering millimeter-level absolute accuracy and all-weather monitoring capability, making it suitable for large-scale regional deformation monitoring [32]. However, its timeliness is limited because GNSS data processing relies on complex algorithms and is time-consuming, while the sampling rate is typically only 1 Hz, making it difficult to capture transient features during the acceleration phase of landslides. In contrast, MEMS sensors can trigger early warning earlier through high-frequency sampling.
Cable displacement meters measure relative displacement across cracks or sliding surfaces through mechanical transmission structures, providing sub-millimeter accuracy and second-level response capability, making them suitable for monitoring landslides where cracks have already been identified [33]. However, they require prior knowledge of the crack location for installation across the fracture surface, rendering them ineffective for newly formed and sudden landslides without visible deformation. In contrast, MEMS sensors can identify potential risks in advance through fused analysis of vibration and tilt signals.
Furthermore, positioning this work within the growing field of MEMS-based landslide monitoring, the GeoMAS system distinguishes itself through its integrated edge-computing architecture and community-warning design [34]. Unlike studies that primarily utilize MEMS sensors as data loggers for post hoc analysis [35], GeoMAS embeds a hybrid denoising and feature extraction pipeline (wavelet packet decomposition combined with Kalman filtering) directly on the device. This enables real-time, on-site interpretation of high-frequency data, a critical step towards autonomous early warning. Additionally, while many technical demonstrations focus on sensor performance alone [36], the spatial separation of the monitoring unit (on the slope) and the alarm unit (in the community) in GeoMAS is a deliberate design choice to generate actionable lead time for end-users. This focus on the complete “sensing-to-alerting” chain, validated through a large-scale physical model test capturing the full failure continuum, represents a significant step towards operationalizing MEMS technology for practical risk reduction.
5.2. Application Advantages
MEMS devices offer distinct advantages in terms of power efficiency, affordability, and scalable installation, making them well-suited to support wider coverage in landslide monitoring [37]. In terms of power consumption, the device operates at ≤ 20 mW during routine monitoring. Supported by dual power sources, solar energy and replaceable batteries, together with an intelligent sleep mechanism, it can function autonomously for extended periods in remote areas without mains electricity, greatly reducing maintenance demand. Its compact form factor allows flexible installation options, such as shallow burial, surface mounting on slopes, or integration with structural components, making it suitable for residential slopes, steep mine benches, and other settings where GNSS or displacement meters are difficult to deploy. In addition, with an IP68 protection rating and a wide operational temperature range of −15 °C to 70 °C, the device maintains reliable performance under harsh weather conditions, including heavy rainfall and freeze–thaw cycles. Combined with its ultra-low power consumption, low hardware cost, and compact form factor, this robustness enables GeoMAS to serve as a promising and scalable solution for wide-area, dense sensor network deployment in community-proximal landslide risk zones.
5.3. Technical Limitations and Future Improvements
Although MEMS-based monitoring offers notable benefits, certain technical limitations persist across the algorithm, hardware, and system levels. One key challenge involves integration-induced drift in displacement estimation. As displacement is derived through double integration of measured acceleration, even minimal sensor noise can be gradually magnified. This is inherent to the discrete sampling of accelerometers, where slight deviations in measurement accumulate over time. Additionally, accurate initialization of velocity and displacement is often difficult in the field, as installation inclination or micro-vibration at startup can introduce initial bias, which subsequently propagates throughout the integration process. To mitigate this issue, implementing a zero-velocity correction strategy is recommended. By taking advantage of stationary intervals, when no slope movement occurs, the system can apply Kalman filtering to compensate for accumulated drift in both velocity and displacement estimates. To quantitatively characterize and improve the accuracy of the displacement estimation method, future work will include controlled laboratory tests where the MEMS-derived displacement is synchronously compared with a high-precision laser displacement sensor.
Another challenge concerns the limited adaptability of warning thresholds. The current system employs fixed thresholds determined from historical background measurements at the test site. While effective in this controlled experiment, their generalizability to diverse field conditions with varying hydrometeorological and environmental noise is limited. Landslide activity is controlled by multiple dynamic factors, including rainfall, temperature, and groundwater variation, meaning that fixed thresholds derived from historical data cannot adequately capture real-time environmental fluctuations. For instance, during the rainy season, elevated soil moisture often increases the ambient vibration baseline; if the threshold remains unchanged, normal background disturbances may be misidentified as precursors, leading to a higher false alarm rate. Moreover, substantial spatial variability in soil properties, slope morphology, and vegetation cover indicates that a single threshold cannot be universally applied. In practical deployments, geological heterogeneity, external interference, and installation differences all influence the amplitude characteristics of acceleration responses. To address these issues, future research should pursue a dynamic threshold learning strategy that incorporates multi-source environmental information (e.g., rainfall and temperature) and leverages machine learning techniques to update thresholds adaptively in response to changing slope conditions.
A further consideration pertains to the fundamental monitoring principle of the MEMS-based device. While it excels at capturing high-frequency dynamic responses (vibrations, tilting rates) that signify the transition from stable creep to accelerated failure, it does not directly measure long-term cumulative displacement relative to a fixed geodetic reference, as is the strength of GNSS or InSAR. This characteristic positions the GeoMAS as a highly sensitive tool for detecting the onset of acceleration phases rather than for monitoring long-term, quasi-static slope movements. Consequently, its optimal application is in integration with other monitoring techniques. For instance, GNSS or crack meters can provide the essential data on cumulative deformation for early risk assessment, while the MEMS device offers critical, real-time insight into the dynamic instability trigger. This synergy is the cornerstone of the proposed “air–space–ground” collaborative monitoring network, aiming to cover the entire landslide evolution spectrum from long-term preparatory stages to imminent collapse.
5.4. Engineering Applications and Future Prospects
MEMS-based systems provide a cost-efficient approach for monitoring newly developed and rapidly occurring geological hazards. The outdoor model experiment in this study successfully demonstrated the feasibility of the GeoMAS system concept, providing a necessary and controlled foundation for validating its core warning capability. However, transitioning from a validated prototype to widespread field deployment requires addressing a series of interconnected practical challenges related to long-term performance, maintenance, integration, and standardization.
5.4.1. Geotechnical Considerations and Site-Specific Adaptation
The dynamics of slope failure and the resulting sensor signals are inherently influenced by the geotechnical properties of the slope material. For instance, saturated fine-grained soils (e.g., clays) may exhibit a more brittle failure mode with a shorter period of precursory creep, potentially generating a distinct signature related to pore-pressure build-up. In contrast, coarse-grained or dry soils might demonstrate a more prolonged phase of progressive failure with clearer vibration anomalies caused by granular rearrangement. Furthermore, the post-failure mobility of the landslide mass (a critical factor for evacuation travel time) is also strongly material-dependent. While the current early-warning algorithm utilizes a generalized motion intensity factor, future optimization could incorporate site-specific geotechnical information (e.g., soil classification, inferred shear strength parameters) to refine threshold calibration and enhance the contextual interpretation of anomaly signals. This underscores the need for site-adaptive deployment strategies where installation and calibration are informed by preliminary geotechnical assessment.
5.4.2. Long-Term Field Durability and Maintenance Protocols
For reliable operation over years in harsh environments, the long-term durability of the monitoring and alarm units must be assured. This involves rigorous validation of component resilience against continuous thermal cycling, moisture ingress, UV radiation, chemical corrosion, and physical impacts from debris or fauna. Beyond durability, establishing a practical maintenance framework is critical for system sustainability. This framework should define clear protocols for: (i) predictive energy management, including battery replacement cycles optimized with solar panel performance; (ii) periodic sensor calibration and diagnostic self-checks to ensure sustained measurement accuracy; and (iii) physical upkeep, such as clearing vegetation overgrowth or re-securing displaced units. Implementing remote health-monitoring features within the edge-computing framework could significantly streamline maintenance.
5.4.3. Integration into Multi-Scale Monitoring Networks and Standardization
The full potential of GeoMAS is realized when integrated into a broader “air–space–ground” collaborative monitoring network. In this hierarchy, GeoMAS serves as the high-frequency, real-time ground sensor for capturing dynamic failure precursors at critical points. Its data should be seamlessly fused with: (i) wide-area, periodic deformation maps from InSAR for regional risk screening; (ii) high-resolution topographic and visual data from UAVs for detailed site modeling and post-event assessment; and (iii) precise, cumulative displacement data from GNSS or crack meters. Developing universal data formats and communication interfaces is key to this integration. Furthermore, to ensure consistent performance, interoperability, and quality across large-scale deployments, the development of technical and procedural standards is imperative. These standards should encompass device specifications, installation guidelines for diverse terrains, data communication protocols, and unambiguous early-warning response protocols for communities and local authorities.
5.4.4. Towards Sustainable and Scalable Deployment
For the technology to be adopted at the scale required to monitor vast numbers of community-proximal slopes, scalability and sustainability must be core design principles. Future iterations should investigate the use of more eco-friendly or recyclable materials to reduce environmental footprint. Research into more efficient, long-life energy harvesting systems (e.g., advanced photovoltaics, micro wind, or vibration energy harvesting) is crucial for minimizing maintenance needs. Ultimately, a holistic lifecycle management plan, from manufacturing to decommissioning, will support the sustainable implementation of dense sensor networks for landslide early warning.
6. Conclusions
This study proposes a novel high-frequency landslide monitoring device and real-time early warning method based on MEMS sensors. By integrating high-frequency sampling with edge computing, combined with Kalman filtering and wavelet threshold denoising, the system achieves millisecond-level dynamic sensing throughout the entire landslide evolution from initial deformation to catastrophic failure. A dynamic graded early warning framework was established using a two-dimensional decision matrix based on the motion intensity factor y and its first derivative y’, combined with a weighted risk coefficient model derived from multi-sensor anomaly levels. Field large-scale landslide model tests were conducted using the developed micro-vibration monitoring unit and alarm unit. The results verified that the monitoring unit can detect precursor signals in advance, while the alarm unit successfully provided graded warnings prior to failure.
With ultra-low power consumption (≤20 mW), an IP68 protection rating, and LoRa-based self-organizing communication, the device is highly adaptable to complex terrain, overcoming the deployment limitations of conventional monitoring systems in densely vegetated areas and residential slope environments. In addition, this technology provides a low-cost and wide-coverage solution for managing newly formed and sudden geological disasters. In the future, through the development of an air–space–ground collaborative monitoring network and standardized deployment, it is expected to promote a shift in landslide early warning strategies from “hidden hazard point management” to “risk zone prevention and control”.
This study has certain limitations that indicate directions for future research. The displacement estimation is susceptible to integration drift over extended periods, and the fixed warning thresholds may not adapt optimally to dynamic environmental conditions across diverse field sites. Furthermore, the device is primarily designed to capture the dynamic precursor signals of accelerating failure rather than to monitor long-term, quasi-static creep. Future investigations will focus on algorithm optimization using machine learning for adaptive thresholds, rigorous field validation alongside traditional sensors, and the development of standards for integration into broader multi-technology monitoring networks as outlined in the discussion.
Author Contributions
Y.L.: original draft, writing—review and editing, conceptualization, formal analysis, methodology, investigation, supervision. L.W.: writing—review and editing, resources, supervision, validation. P.L.: writing—review and editing, data curation, methodology. Y.Y.: writing—review and editing, data curation, resources, validation. All authors have read and agreed to the published version of the manuscript.
Funding
This work was financially supported by the Technology Innovation Center of Geohazard Automatic Monitoring, Ministry of Natural Resources (Chongqing Institute of Geology and Mineral Resources), China (No. TICG-K2024008).
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The data presented in the article can be obtained by contacting the corresponding author.
Acknowledgments
The authors would like to express their sincere gratitude to Yi Li of Chongqing Huadi Resources and Environment Technology for their valuable contributions to the manuscript through writing—review and editing, and investigation.
Conflicts of Interest
The authors declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| MEMS | Micro Electro Mechanical System |
| GeoMAS | Geological MEMS Alert System |
| LoRa | Long Range Radio |
| GNSS | Global Navigation Satellite System |
| UAV | Unmanned Aerial Vehicle |
References
- Guo, Z.Z.; Tian, B.X.; Zhu, Y.H.; He, J.; Zhang, T.L. How do the landslide and non-landslide sampling strategies impact landslide susceptibility assessment?—A catchment-scale case study from China. J. Rock Mech. Geotech. Eng. 2024, 16, 877–894. [Google Scholar] [CrossRef] [Scilit]
- Deng, Y.K.; Tian, W.M.; Xiao, T.; Hu, C.; Yang, H. High-quality pixel selection applied for natural scenes in gb-sar interferometry. Remote Sens. 2021, 13, 1617. [Google Scholar] [CrossRef] [Scilit]
- Lu, J.G.; He, Y.; Zhang, L.F.; Zhang, Q.; Gao, B.H.; Chen, H.S.; Fang, Y.M. Ensemble learning landslide susceptibility assessment with optimized non-landslide samples selection. Geomat. Nat. Hazards Risk 2024, 15, 2378176. [Google Scholar] [CrossRef] [Scilit]
- Xiao, T.; Huang, W.; Wang, L.C.; Yang, B.B.; Qin, Z.H.; Liu, X.D.; Xiao, Y.B. Uncertainty-Aware Ensemble Learning and Dynamic Threshold Optimization for Landslide Susceptibility Mapping. Comput. Geosci. 2025, 206, 106042. [Google Scholar] [CrossRef] [Scilit]
- Yang, B.B.; Xiao, T.; Wang, L.Q.; Huang, W. Using complementary ensemble empirical mode decomposition and gated recurrent unit to predict landslide displacements in dam reservoir. Sensors 2022, 22, 1320. [Google Scholar] [CrossRef] [Scilit]
- Wei, R.L.; Ye, C.M.; Ge, Y.G.; Li, Y. An attention-constrained neural network with overall cognition for landslide spatial prediction. Landslides 2022, 19, 1087–1099. [Google Scholar] [CrossRef] [Scilit]
- Tian, H.H.; Xiao, T.; Shu, B.; Peng, Z.W.; Meng, D.B. Temporal and spatial pattern analysis and susceptibility assessment of geological hazards in Hunan Province of China from 2015 to 2022. Stoch. Environ. Res. Risk Assess. 2024, 38, 1453–1474. [Google Scholar] [CrossRef] [Scilit]
- Yu, L.B.; Wang, Y.; Pradhan, B. Enhancing landslide susceptibility mapping incorporating landslide typology via stacking ensemble machine learning in Three Gorges Reservoir, China. Geosci. Front. 2024, 15, 101802. [Google Scholar] [CrossRef] [Scilit]
- Yu, D.Y.; He, Z. Digital twin-driven intelligence disaster prevention and mitigation for infrastructure: Advances, challenges, and opportunities. Nat. Hazards Res. 2022, 112, 1–36. [Google Scholar] [CrossRef] [Scilit]
- Xu, H.; Shu, B.; Zhang, Q.; Du, Y.; Zhang, J.; We, T.; Xiong, G.H.; Dai, X.L.; Wang, L. Site selection for landslide GNSS monitoring stations using InSAR and UAV photogrammetry with analytical hierarchy process. Landslides 2024, 21, 791–805. [Google Scholar] [CrossRef] [Scilit]
- Cheng, Z.; Gong, W.P.; Jaboyedoff, M.; Chen, J.; Derron, M.-H.; Zhao, F.M. Landslide Identification in UAV Images Through Recognition of Landslide Boundaries and Ground Surface Cracks. Remote Sens. 2025, 17, 1900. [Google Scholar] [CrossRef] [Scilit]
- Chen, H.; Wu, H.G. Method for determining the position of landslide slip-surface with a typical inclinometric curves. J. Mt. Sci. 2024, 21, 413–432. [Google Scholar] [CrossRef] [Scilit]
- Tsatsaris, A.; Kalogeropoulos, K.; Stathopoulos, N. Geoinformation technologies in support of environmental hazards monitoring under climate change: An extensive review. ISPRS Int. J. Geo-Inf. 2021, 10, 94. [Google Scholar] [CrossRef] [Scilit]
- Liu, Z.Y.; Huang, J.; Li, Y.H.; Liu, X.K.; Qiang, F.; He, Y.P. A Bibliometric Analysis of Geological Hazards Monitoring Technologies. Sustainability 2025, 17, 962. [Google Scholar] [CrossRef] [Scilit]
- Franceschini, R.; Nocentini, N.; Rosi, A.; Tunini, L.; Zuliani, D.; Peressi, G.; Rossi, G. Deriving rainfall thresholds with XAI and GNSS measurements for a large landslide. Landslides 2025, 1–14. [Google Scholar] [CrossRef] [Scilit]
- Geirsson, H.; Sæmundsson, Þ. The role of GNSS monitoring in landslide research. In GNSS Monitoring of the Terrestrial Environment; Elsevier: Amsterdam, The Netherlands, 2024; pp. 243–255. [Google Scholar] [CrossRef] [Scilit]
- Wen, H.J.; Huang, J.H.; Qian, L.; Li, Z.H.; Zhang, Y.L.; Zhang, J.L. The spatial-temporal evolution patterns of landslide-oriented resilience in mountainous city: A case study of Chongqing, China. J. Environ. Manag. 2024, 370, 122963. [Google Scholar] [CrossRef] [Scilit]
- Liu, S.H.; Du, J.; Yin, K.L.; Zhou, C.; Huang, C.C.; Jiang, J.; Yu, J. Regional early warning model for rainfall induced landslide based on slope unit in Chongqing, China. Eng. Geol. 2024, 333, 107464. [Google Scholar] [CrossRef] [Scilit]
- Stefaniak, K.; Wierzbicki, J.; Ksit, B.; Szymczak-Graczyk, A. Biocementation as a pro-ecological method of stabilizing construction subsoil. Energies 2023, 16, 2849. [Google Scholar] [CrossRef] [Scilit]
- Hossain, N.; Al, M.M.Z.; Hossain, A.; Rahman, M.K.; Islam, M.S.; Tasnim, R.M.; Md, H. Advances of materials science in MEMS applications: A review. Results Eng. 2024, 22, 102115. [Google Scholar] [CrossRef] [Scilit]
- Gogolik, S.; Kopras, M.; Szymczak-Graczyk, A.; Tschuschke, W. Experimental evaluation of the size and distribution of lateral pressure on the walls of the excavation support. J. Build. Eng. 2023, 73, 106831. [Google Scholar] [CrossRef] [Scilit]
- Mpiere, D.; Tehami, K.; Coulibaly, I.; Mbaiogaou, C. Assessing the integration of the Sendai framework, sustainable development goals, and the Paris agreement in advancing disaster risk reduction and sustainable development: Insights from an African perspective. J. Geosci. Environ. Prot. 2025, 13, 350–368. [Google Scholar] [CrossRef]
- Wu, S.S.; Tao, Z.G.; Zhang, L.; Chen, S. Early Warning for Stepwise Landslides Based on Traffic Light System: A Case Study in China. Remote Sens. 2024, 16, 4391. [Google Scholar] [CrossRef] [Scilit]
- Kopras, M.; Buczkowski, W.; Szymczak-Graczyk, A.; Walczak, Z.; Gogolik, S. Experimental validation of deflections of temporary excavation support plates with the use of 3D modelling. Materials 2022, 15, 4856. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Chen, J.H.; Guo, Q.B.; Yang, J.S.; Luo, J.; Wang, L. Seismic landslide susceptibility assessment based on game theory combination weighting and information volume model: A case study of Luding earthquake high-intensity area. Sādhanā 2025, 50, 6. [Google Scholar] [CrossRef] [Scilit]
- Fang, Z.C.; Wang, Y.; Van, W.C.; Lombardo, L. Space–time landslide susceptibility modeling based on data-driven methods. Math. Geosci. 2024, 56, 1335–1354. [Google Scholar] [CrossRef] [Scilit]
- Zheng, W.J.; Hu, J.; Lu, Z.; Hu, X.; Sun, Q.; Liu, J.H.; Huang, B. Enhancing 4-D landslide monitoring and block interaction analysis with a Novel Kalman-filter-based InSAR approach. JGR Earth Surf. 2024, 129, e2024JF007923. [Google Scholar] [CrossRef] [Scilit]
- Huang, L.; Li, D.; Yan, H.Y.; Wang, K.X.; Huang, Z.Q. Dual-window fusion filtering with adaptive anomaly correction for real-time GNSS landslide monitoring. Meas. Sci. Technol. 2025, 36, 096104. [Google Scholar] [CrossRef] [Scilit]
- Liu, J.J.; Liu, H.D.; Luo, J.M.; Chen, J.X.; Wang, H. Tilting deformation analysis and instability prediction of arch-locked-segment landslides induced by rainfall. Sci. Rep. 2025, 15, 3449. [Google Scholar] [CrossRef] [Scilit]
- Lv, J.C.; Zhang, R.; Bao, X.; Wu, R.Z.; Hong, R.K.; He, X.; Liu, G.X. Time-series InSAR landslide three-dimensional deformation prediction method considering meteorological time-delay effects. Eng. Geol. 2025, 350, 107986. [Google Scholar] [CrossRef] [Scilit]
- Li, G.M.; Zhang, Y.; Zhang, Y.H. Landslide hazard prediction based on UAV remote sensing and discrete element model simulation—Case from the Zhuangguoyu landslide in Northern China. Remote Sens. 2024, 16, 3887. [Google Scholar] [CrossRef] [Scilit]
- Li, D.X.; Du, Y.; Zhang, Q.; Huang, G.W.; Wang, L.; Bai, Z.W.; Li, Y.; Zhang, J. Low-cost miniaturized GNSS antenna for landslide monitoring and application in Baige landslide (western China). Adv. Space Res. 2025, 76, 128–142. [Google Scholar] [CrossRef] [Scilit]
- Lu, K.; Li, F.; Pan, J.W.; Li, K.T.; Li, Z.Y.; Wang, P. Structural characterization and attempted displacement interpretation of the Baishuihe landslide using integrated geophysical methods. Eng. Geol. 2024, 336, 107568. [Google Scholar] [CrossRef] [Scilit]
- Cina, A.; Manzino, A.M.; Bendea, I.H. Improving GNSS landslide monitoring with the use of low-cost MEMS accelerometers. Appl. Sci. 2019, 9, 5075. [Google Scholar] [CrossRef] [Scilit]
- Pajalić, S.; Peranić, J.; Maksimović, S.; Čeh, N.; Jagodnik, V.; Arbanas, Ž. Monitoring and data analysis in small-scale landslide physical model. Appl. Sci. 2021, 11, 5040. [Google Scholar] [CrossRef] [Scilit]
- Casagli, N.; Intrieri, E.; Tofani, V.; Gigli, G.; Raspini, F. Landslide detection, monitoring and prediction with remote-sensing techniques. Nat. Rev. Earth Environ. 2023, 4, 51–64. [Google Scholar] [CrossRef] [Scilit]
- Najafabadi, H.R.; Goto, T.G.; Martins, T.C.; Tsuzuki, M.S.; Barari, A. Designing MEMS accelerometer for enhanced sensitivity and reduced cross-sensitivity in landslide monitoring. Measurement 2024, 226, 114092. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.