Article

Enhancing Mechanical Safety in Suspension Systems: Harnessing Control Lyapunov and Barrier Functions for Nonlinear Quarter Car Model via Quadratic Programs


1
Department of Mechanical Engineering, Tafila Technical University, Tafila 66110, Jordan
2
Chair of Artificial Intelligence and Aerodynamics, School of Mechanical Engineering and Automation, Harbin Institute of Technology, Shenzhen 518055, China
3
Guangdong Provincial Key Laboratory of Intelligent Morphing Mechanisms and Adaptive Robotics, Harbin Institute of Technology, Shenzhen 518055, China
*
Author to whom correspondence should be addressed.
Appl. Sci. 2024, 14(8), 3140; https://doi.org/10.3390/app14083140
Submission received: 23 February 2024 / Revised: 26 March 2024 / Accepted: 27 March 2024 / Published: 9 April 2024
(This article belongs to the Section Mechanical Engineering)

Abstract

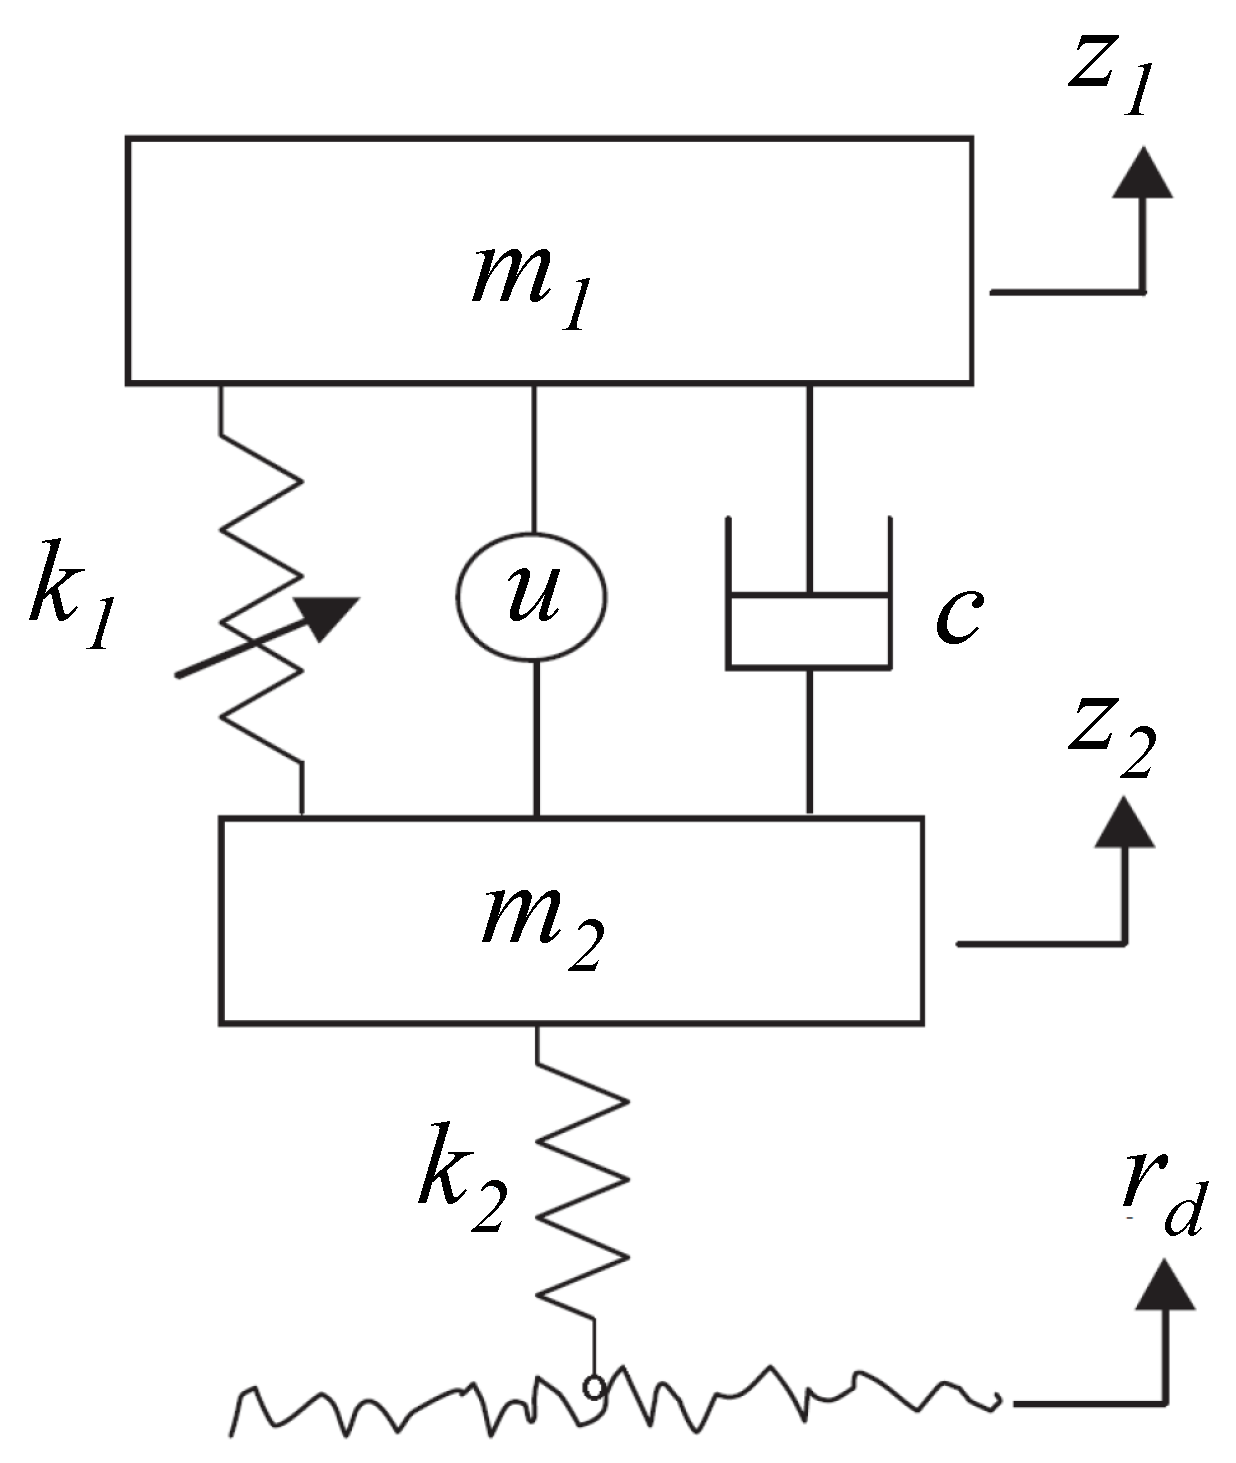
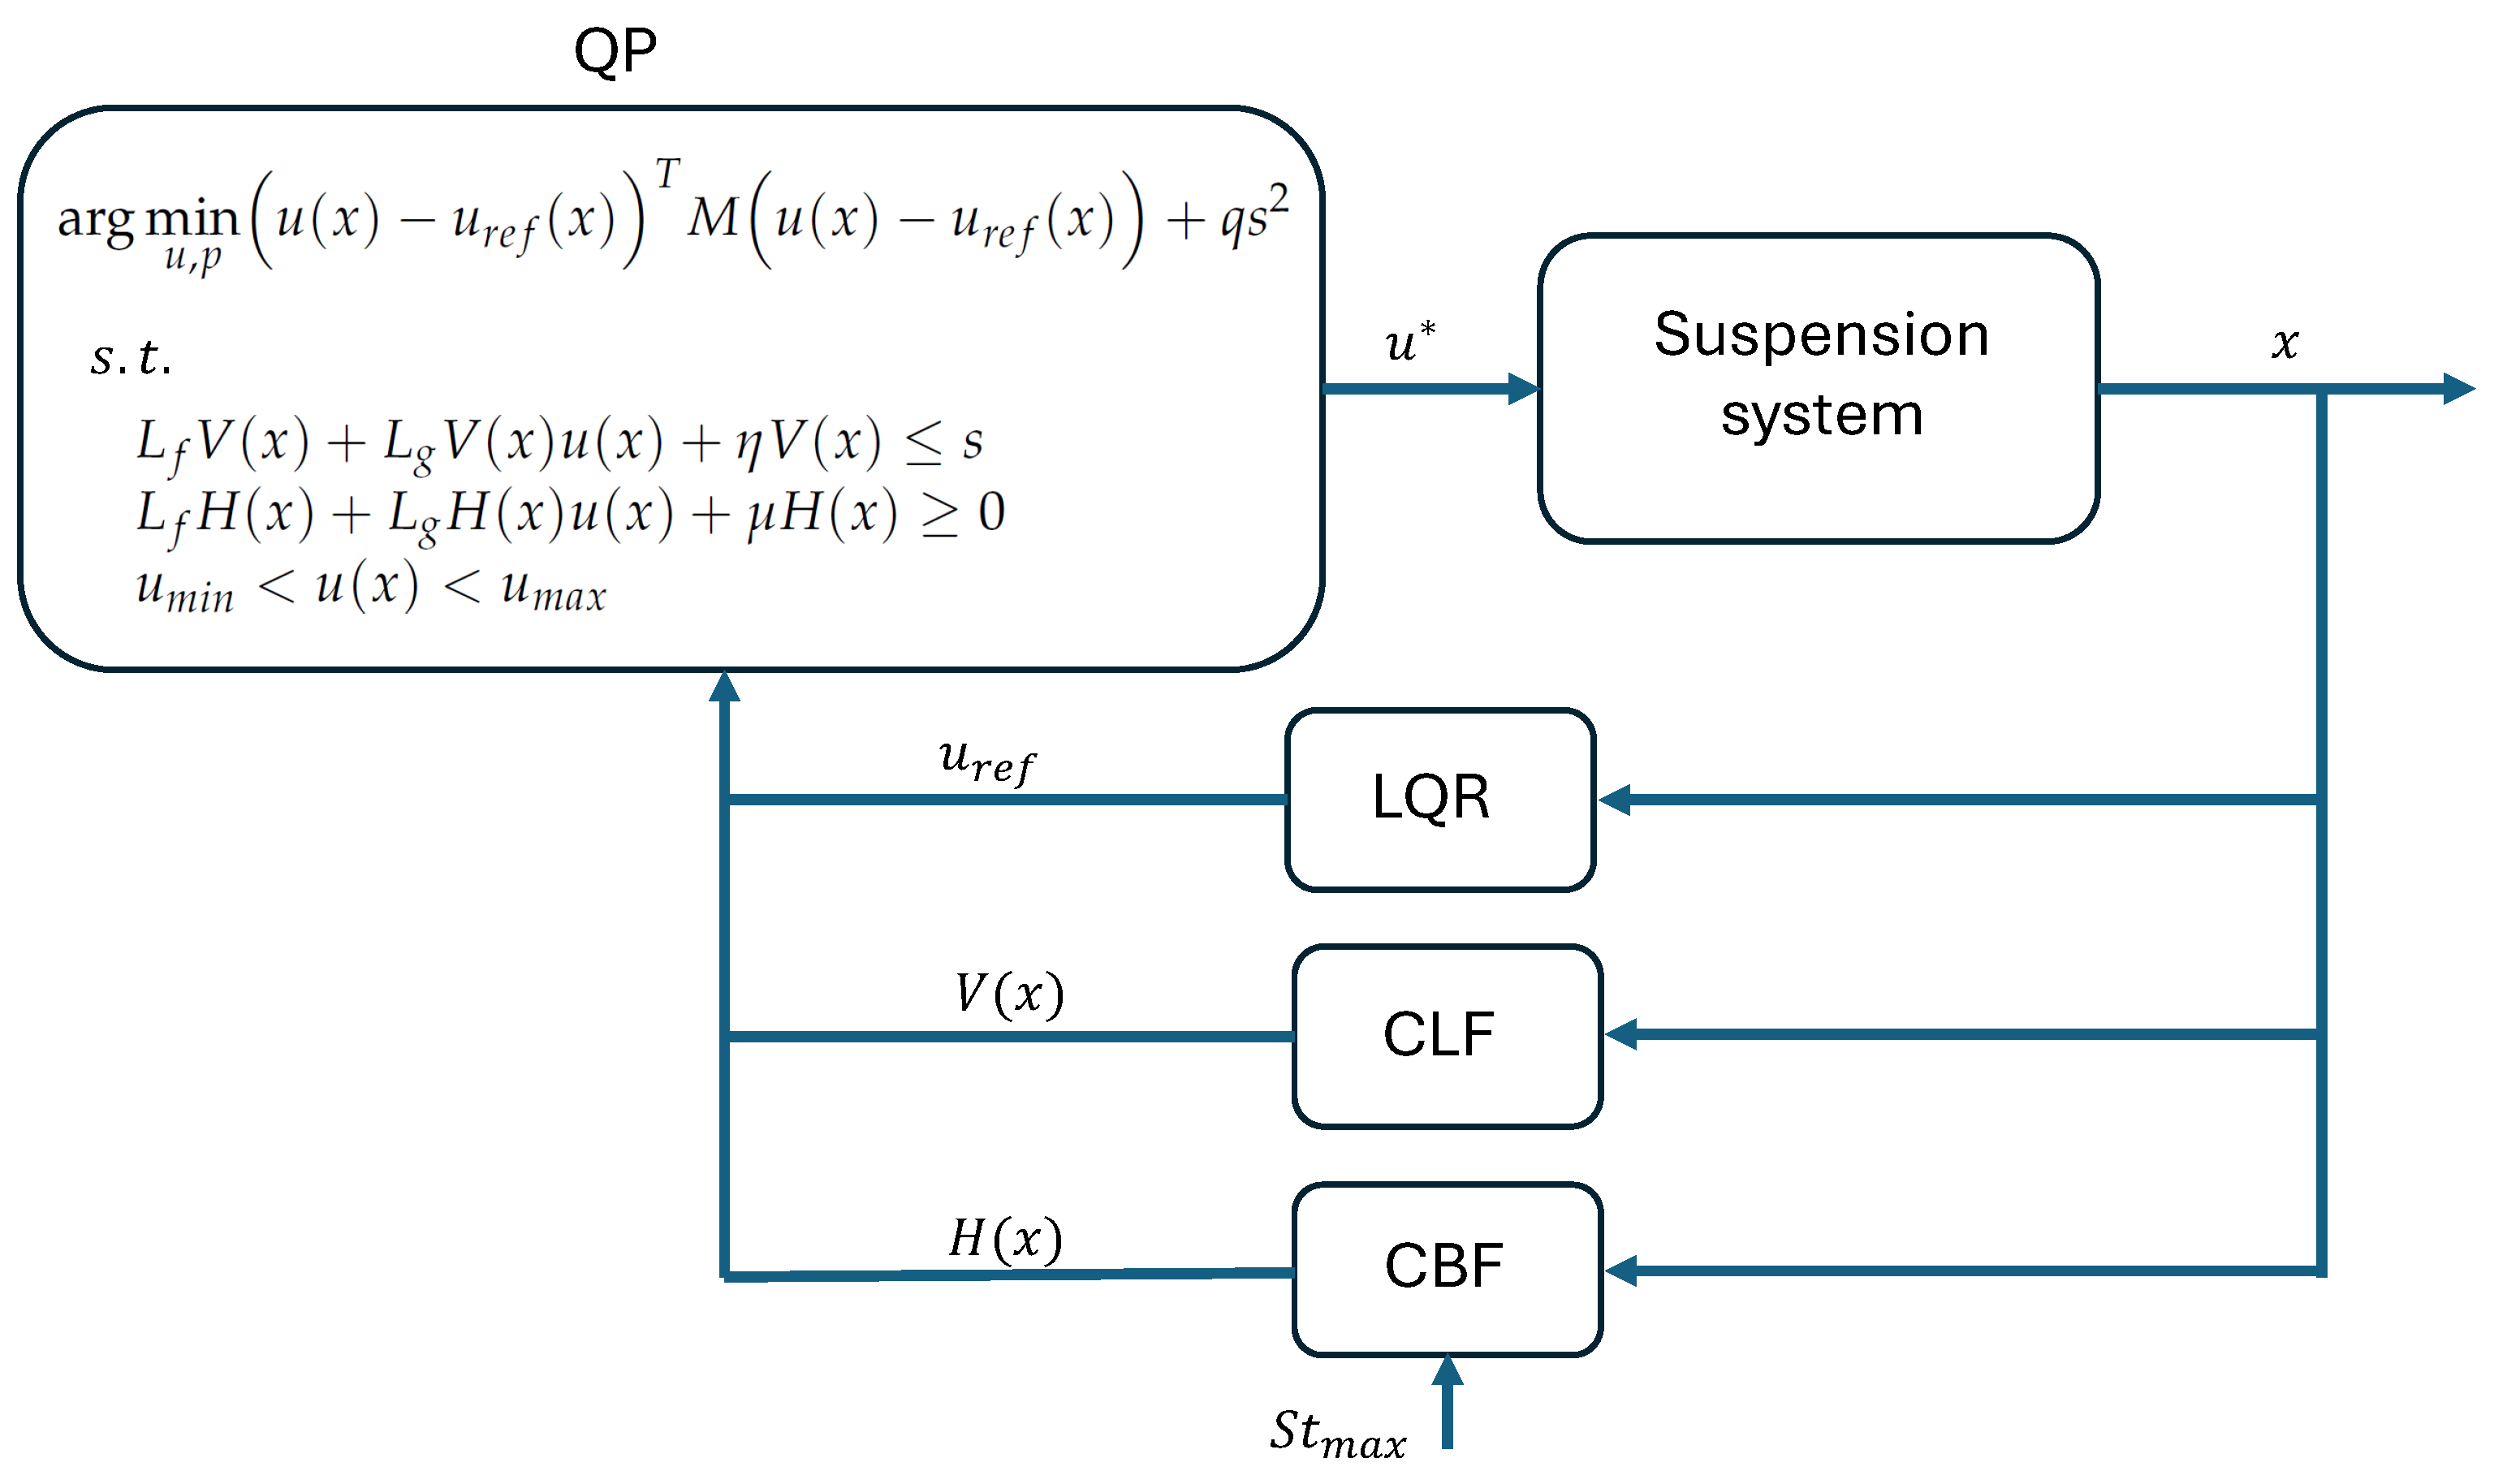
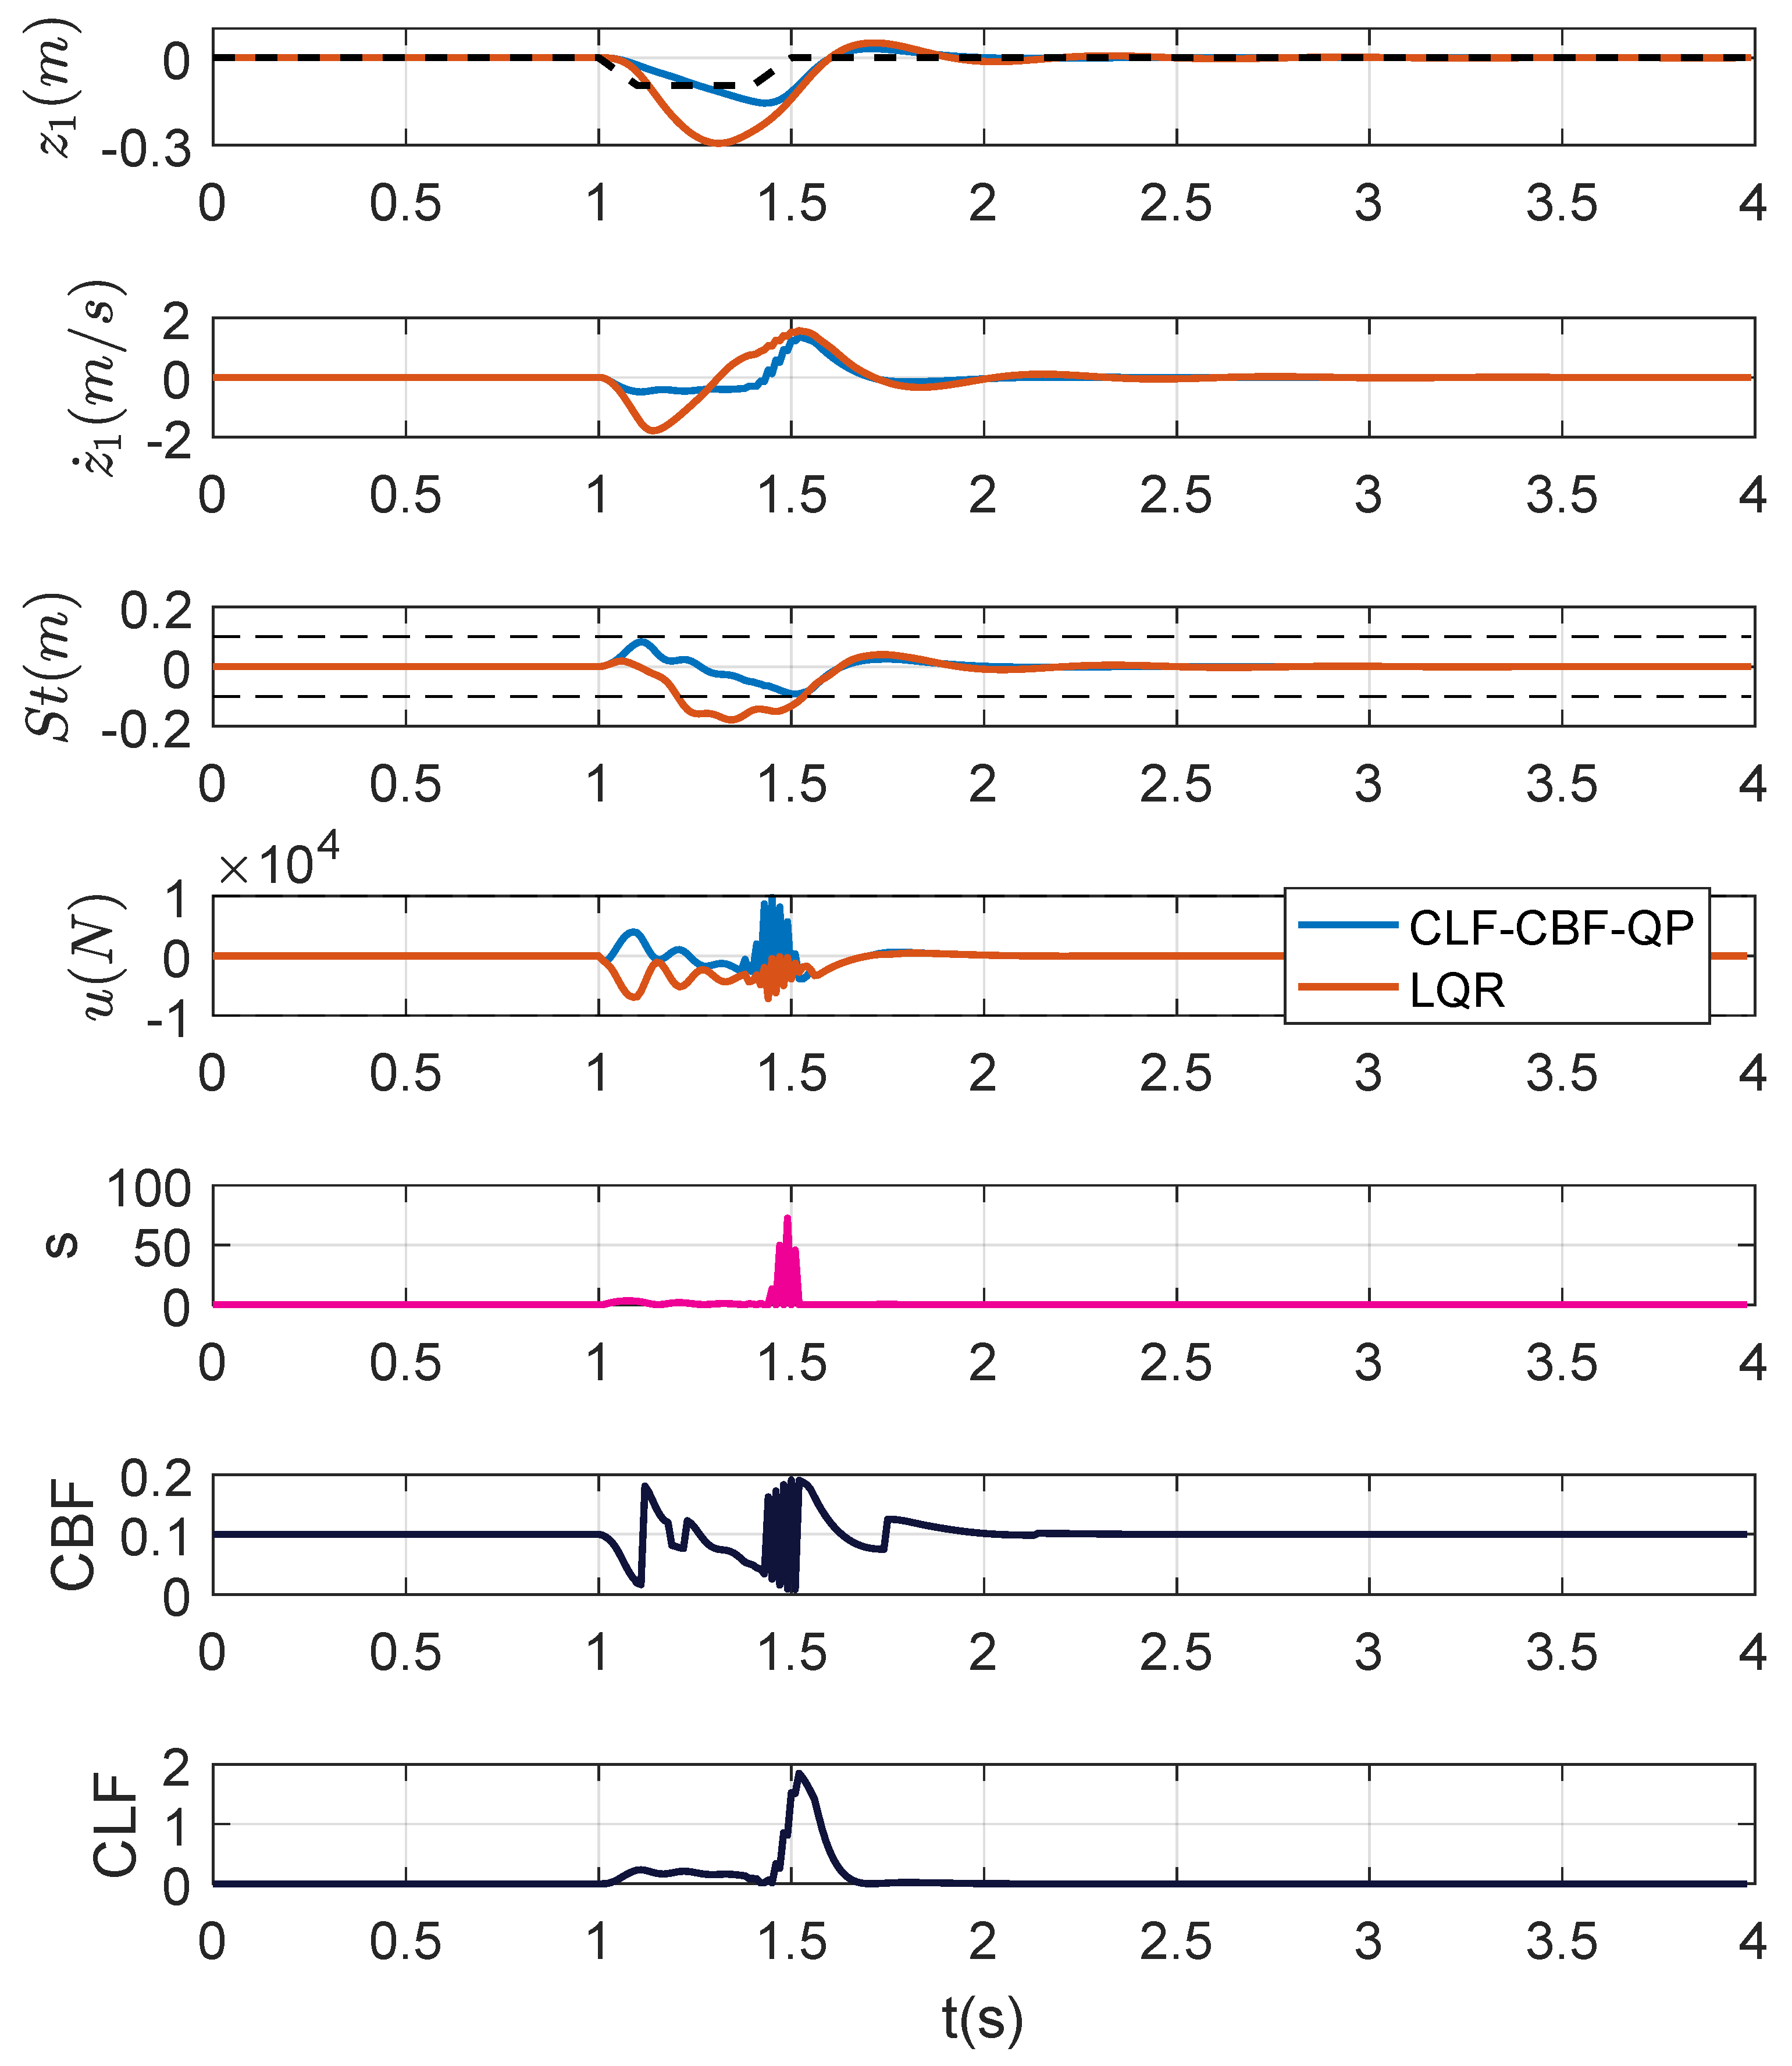
Limiting the suspension stroke in vehicles holds critical and conceivable benefits. It is crucial for the safety, stability, ride comfort, and overall performance of the vehicle. Furthermore, it improves the reliability of suspension components and maintains consistent handling during regular and rough driving conditions. Hence, the design of a safety-critical controller to limit the suspension stroke for active suspension systems is of high importance. In this study, we employed a quarter-car model that incorporates a suspension spring with cubic nonlinearity. The proposed safety-critical controller is the control Lyapunov function–control barrier function–quadratic programming (CLF-CBF-QP). Initially, we designed the reference controller as a linear quadratic regulator (LQR) controller based on the linearized quarter-car model. The reference state-feedback LQR controller simplified the design of the control Lyapunov function. Consequently, from the nonlinear model, we construct a simple control Lyapunov function that relies only on the sprung mass velocity to have a relative degree of one. The CLF intends to improve the performance by considering the nonlinearity and via online optimization. We then formulate the control barrier function to restrict the suspension stroke from breaching its limits. To assess the effectiveness of the proposed controller, we present two challenging road inputs for the nonlinear quarter-car model when employing CLF-CBF-QP and LQR controllers. The CLF-CBF-QP findings surpassed the LQR controller in terms of safety and performance. This study highlights the immense potential of CLF-CBF-QP for suspension systems, improving the time-domain performance, limiting the suspension stroke, and guaranteeing safety.
Keywords: active suspension control; safety-critical controller; CLF-CBF-QP; limiting suspension stroke active suspension control; safety-critical controller; CLF-CBF-QP; limiting suspension stroke