


Abstract
A sealless pump, also known as a wet rotor pump or a canned pump, requires a stationary sleeve in the air gap to protect the stator from a medium that flows around the rotor and the pump impeller. Since the sleeve is typically made from a non-magnetic electrically conductive material, the time-varying magnetic flux density in the air gap creates an eddy current loss in the sleeve. Precise assessment of this loss is crucial for the design of the pump. This paper presents a method for calculating the eddy current loss in such sleeves by using only a two-dimensional (2D) finite element method (FEM) solver. The basic idea is to use the similar structure of Ampère’s circuital law and Faraday’s law of induction to solve eddy current problems with a magnetostatic solver. The theoretical background behind the proposed method is explained and applied to the sleeve of a sealless pump. Finally, the results obtained by a 2D FEM approach are verified by three-dimensional FEM transient simulations.
1. Introduction
An electrical machine, either synchronous or induction, with an internal rotor and a stationary sleeve fixed to the inner side of the stator is typically used as a sealless pump [1]. Optionally, an additional sleeve is mounted on the rotor to reduce the friction caused by rotor cavities. Sealless pumps are used in circulating systems that require a leak-proof enclosure, where glands and seals may not be reliable enough. Although such pumps have clear advantages in hazardous applications, they face the challenge of finding a suitable non-magnetic material for the sleeves. Since electrically non-conductive materials such as carbon graphite may not be suitable in certain applications, materials with a low electrical conductivity such as titanium, silicone steel, SUS304, SUS316L, Inconel 718, Hastelloy C, or stainless steel 1.4571 might be used [2,3,4]. Regardless of the type of the machine, the time-varying magnetic flux density in the air gap leads to substantial eddy current losses in electrically conductive sleeves. These losses can significantly outweigh the copper and iron losses, thereby reducing the efficiency of the machine. Thus, minimizing the eddy current loss in each such sleeve should be the main focus of the design and optimization of every sealless pump [4,5].
An assessment of the eddy current loss in thin electrically conductive sleeves can be approached purely theoretically as in [6]. In this work the application of the field theory leads to a classical boundary-value problem that accounts for the dimensions of the sleeve and the length of the overhang. The eddy current loss problem is commonly formulated numerically and adopted for use with boundary and finite element methods [7,8]. On the contrary, in some cases a volume integral formulation using facet elements is translated into an equivalent lumped element network as demonstrated in [9].
Analytical models are typically fast to evaluate, but often lack accuracy due to some geometrical assumptions and a limited number of spatial harmonics of the magnetic flux density considered in the calculation of the eddy current loss. On the other hand, the two- or three-dimensional (3D or 2D) finite element method (FEM) provides a variable accuracy that depends on the number of finite elements employed in the calculation. As such, it can provide a high accuracy at the expense of the computation time and complexity. This paper tries to make a compromise between speed and accuracy by using a magnetostatic 2D FEM solver while taking advantage of the similarity between the differential forms of Faraday’s law of induction and Ampère’s circuital law for magnetostatics. The functionality of the proposed method is demonstrated for a permanent magnet synchronous machine with embedded rotor magnets. The main advantage of the proposed method is its easy integration in the simulation workflow of genetic algorithms for multi-objective optimizations, such as those in the System Model Space (SyMSpace) [10].
2. Theoretical Background
2.1. Structural Similarity of Ampère’s Circuital Law and Faraday’s Law of Induction
Ampère’s circuital law defines the relationship between the magnetic flux density (), the current density (), and the electric field (). Its differential form can be written as
where is the magnetic permeability of free space and is the electrical permittivity of free space. The term is also referred to as the displacement current. In electrical machines this displacement current can be neglected if conductors with high electrical conductivity are used, such that
applies, where denotes the angular speed. Therefore, the electromagnetic problem is reduced to a magnetostatic one
which can be easily handled by a finite element solver [11]. For a more efficient and smart simulation workflow it is beneficial to be able to solve eddy current problems by using a magnetostatic solver. Solutions of eddy current problems are obtained by solving Faraday’s law of induction, which can be written in its differential form as
Equation (4) describes a time-varying problem which cannot be directly solved by a magnetostatic solver. Nevertheless, the structure of (3) and (4) can be generalized in the form of
2.2. Calculation of Eddy Current Loss
The magnetic energy () can be obtained from the magnetic energy density () in the volume of the sleeve () as
In general, can be obtained from the magnitude of the magnetic field strength (H) as
In magnetically non-conductive materials used for the aforementioned sleeves, the relationship between H and the magnitude of (B) can be taken as , so that (8) can be written in terms of B as
Thus, if the solution of (3) obtained by a magnetostatic solver refers to , then (7) according to (9) can be expressed in terms of the magnitude of (E) as
and solved by an FEM solver such as FEMM [11]. The eddy current loss () in is defined by Joule’s law based on and the eddy current density () or either of them via the electrical conductivity of the sleeve () as
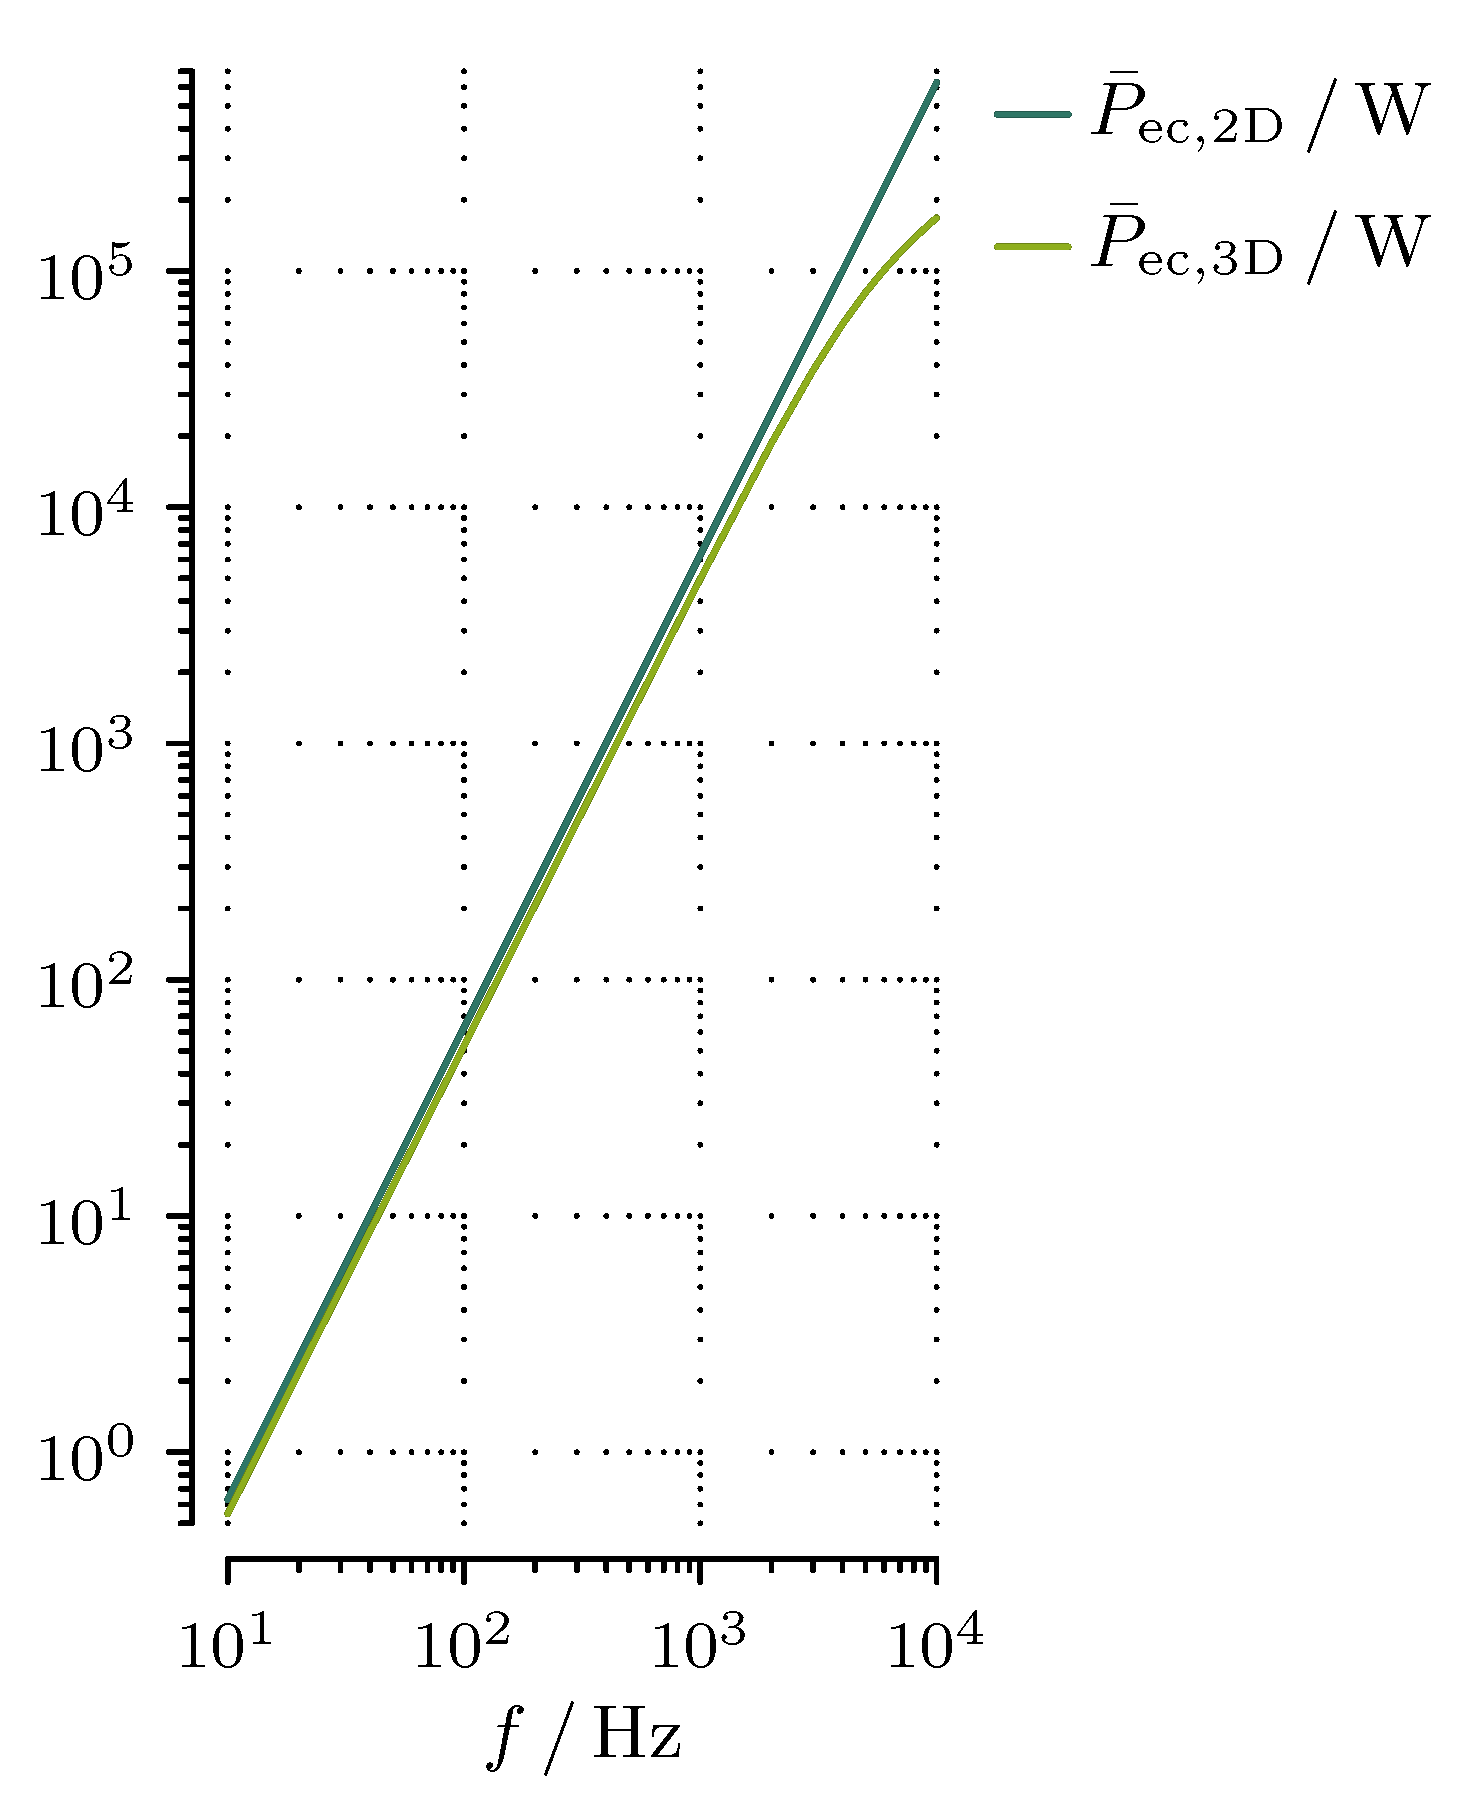
The attenuation of the changing excitation field caused by the magnetic field created by the induced eddy currents that opposes the changing excitation field is neglected, which in turn limits the application of this method to a certain frequency range. This limitation is demonstrated in the simulation results.
3. Simulation Methodology
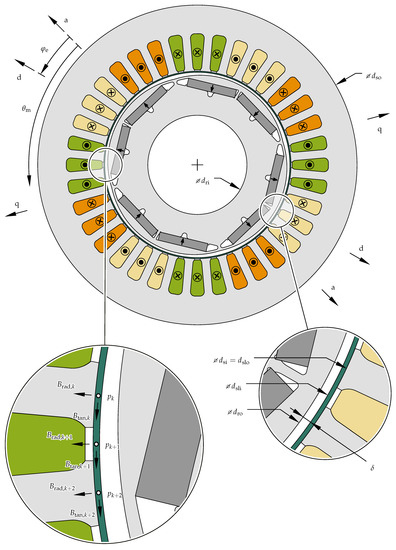
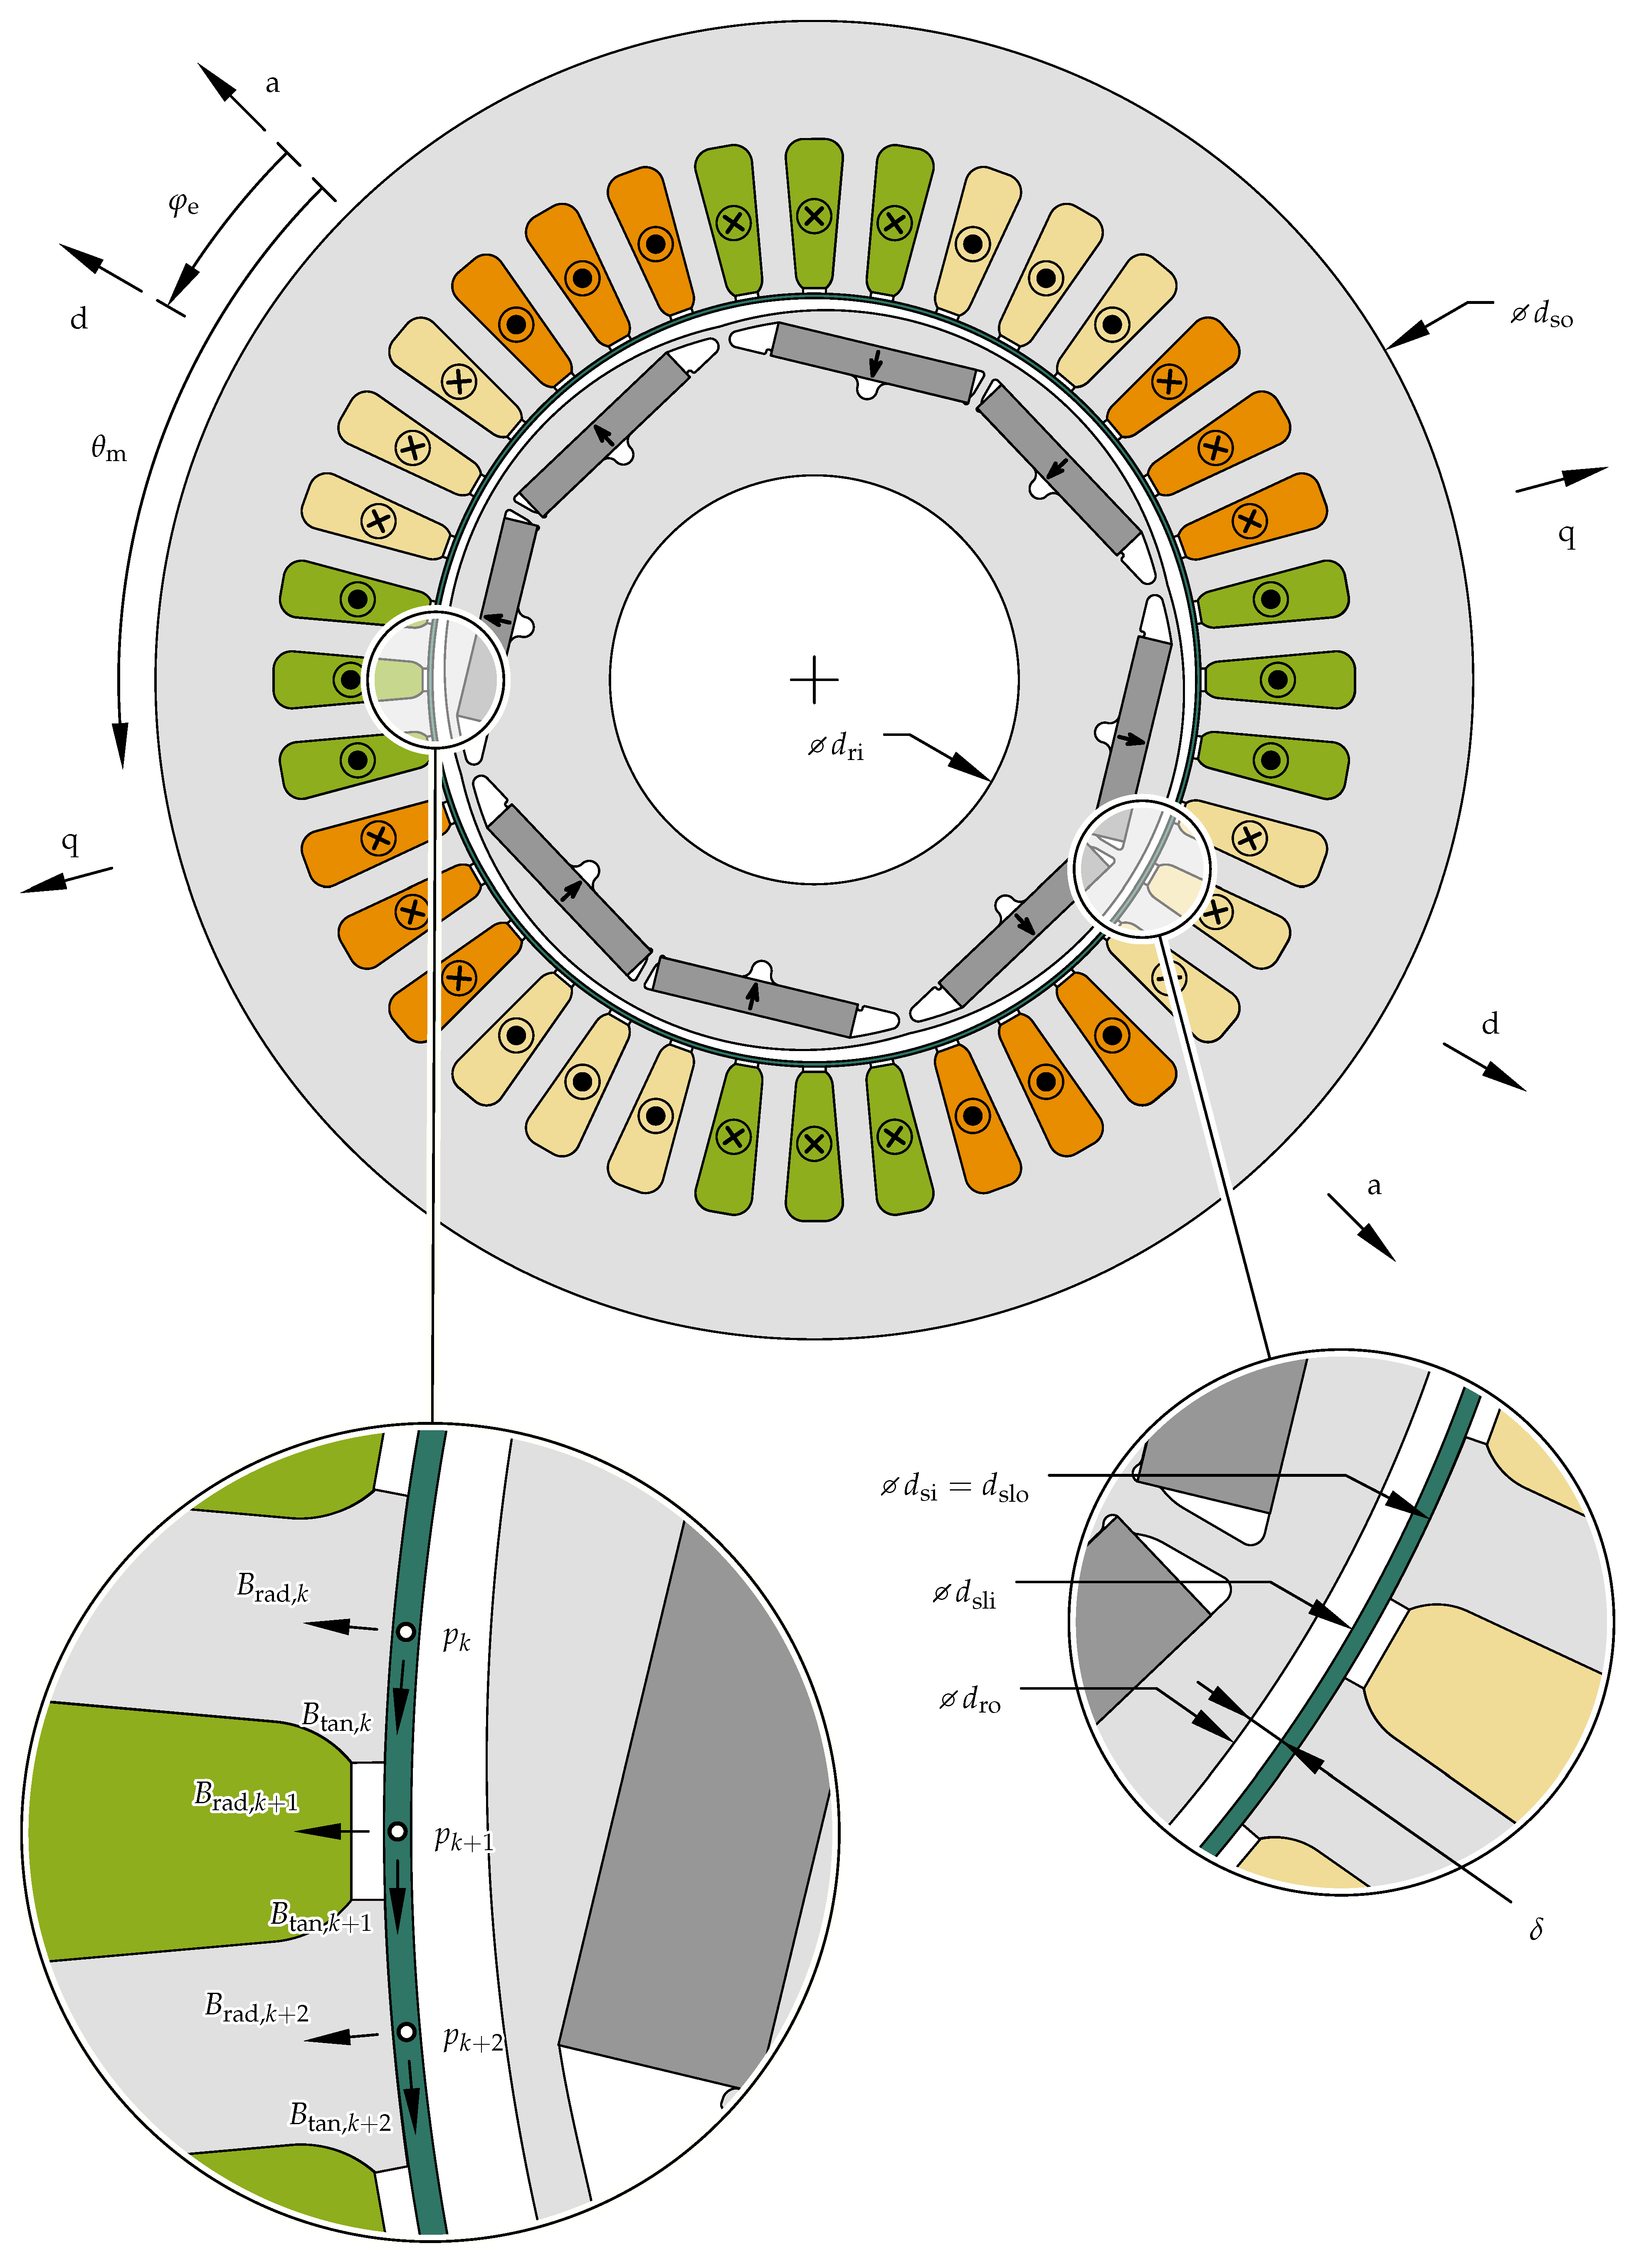
The proposed method is implemented in SyMSpace for the geometry shown in Figure 1. Although in Figure 1 it can be seen that the machine has 2 pole pairs () and 36 slots, the remaining machine parameters including the sleeve parameters are listed in Table 1 and Table 2.
Figure 1.
The radial cross section of the observed machine with key parameters and an example of evaluation points at the mid radius of the sleeve.
Table 1.
Machine parameters for Variant 1–3.
Table 2.
Machine parameters.
Since the axial length of the lamination stack () determines the nominal power of the machine (), the three variants listed in Table 2 were analyzed to determine the influence of the axial length of the sleeve () on .
To calculate , evaluation points shown in Figure 1 are defined in the SyMSpace project as coordinates at the mid radius of the sleeve () along its circumference. Each evaluation point () is defined based on , the total number of evaluation points along the circumference of the sleeve (K) that needs to be specified, and the number of each evaluation point (k) as
After being defined, the evaluation points are evaluated in SyMSpace by means of FEMM. From the obtained results for in the and the direction ( and ), the radial component of () at each evaluation point is calculated as
while the tangential component of () is calculated as
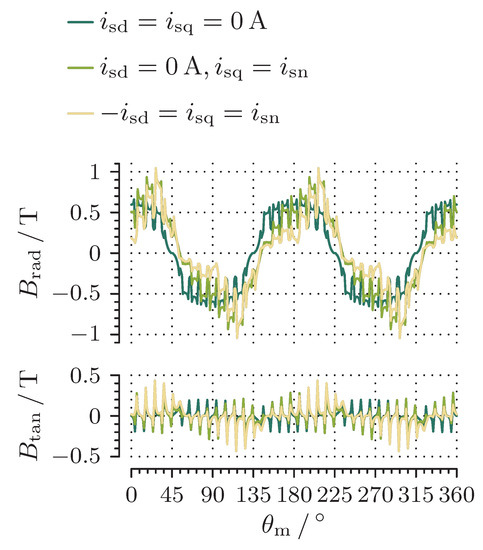
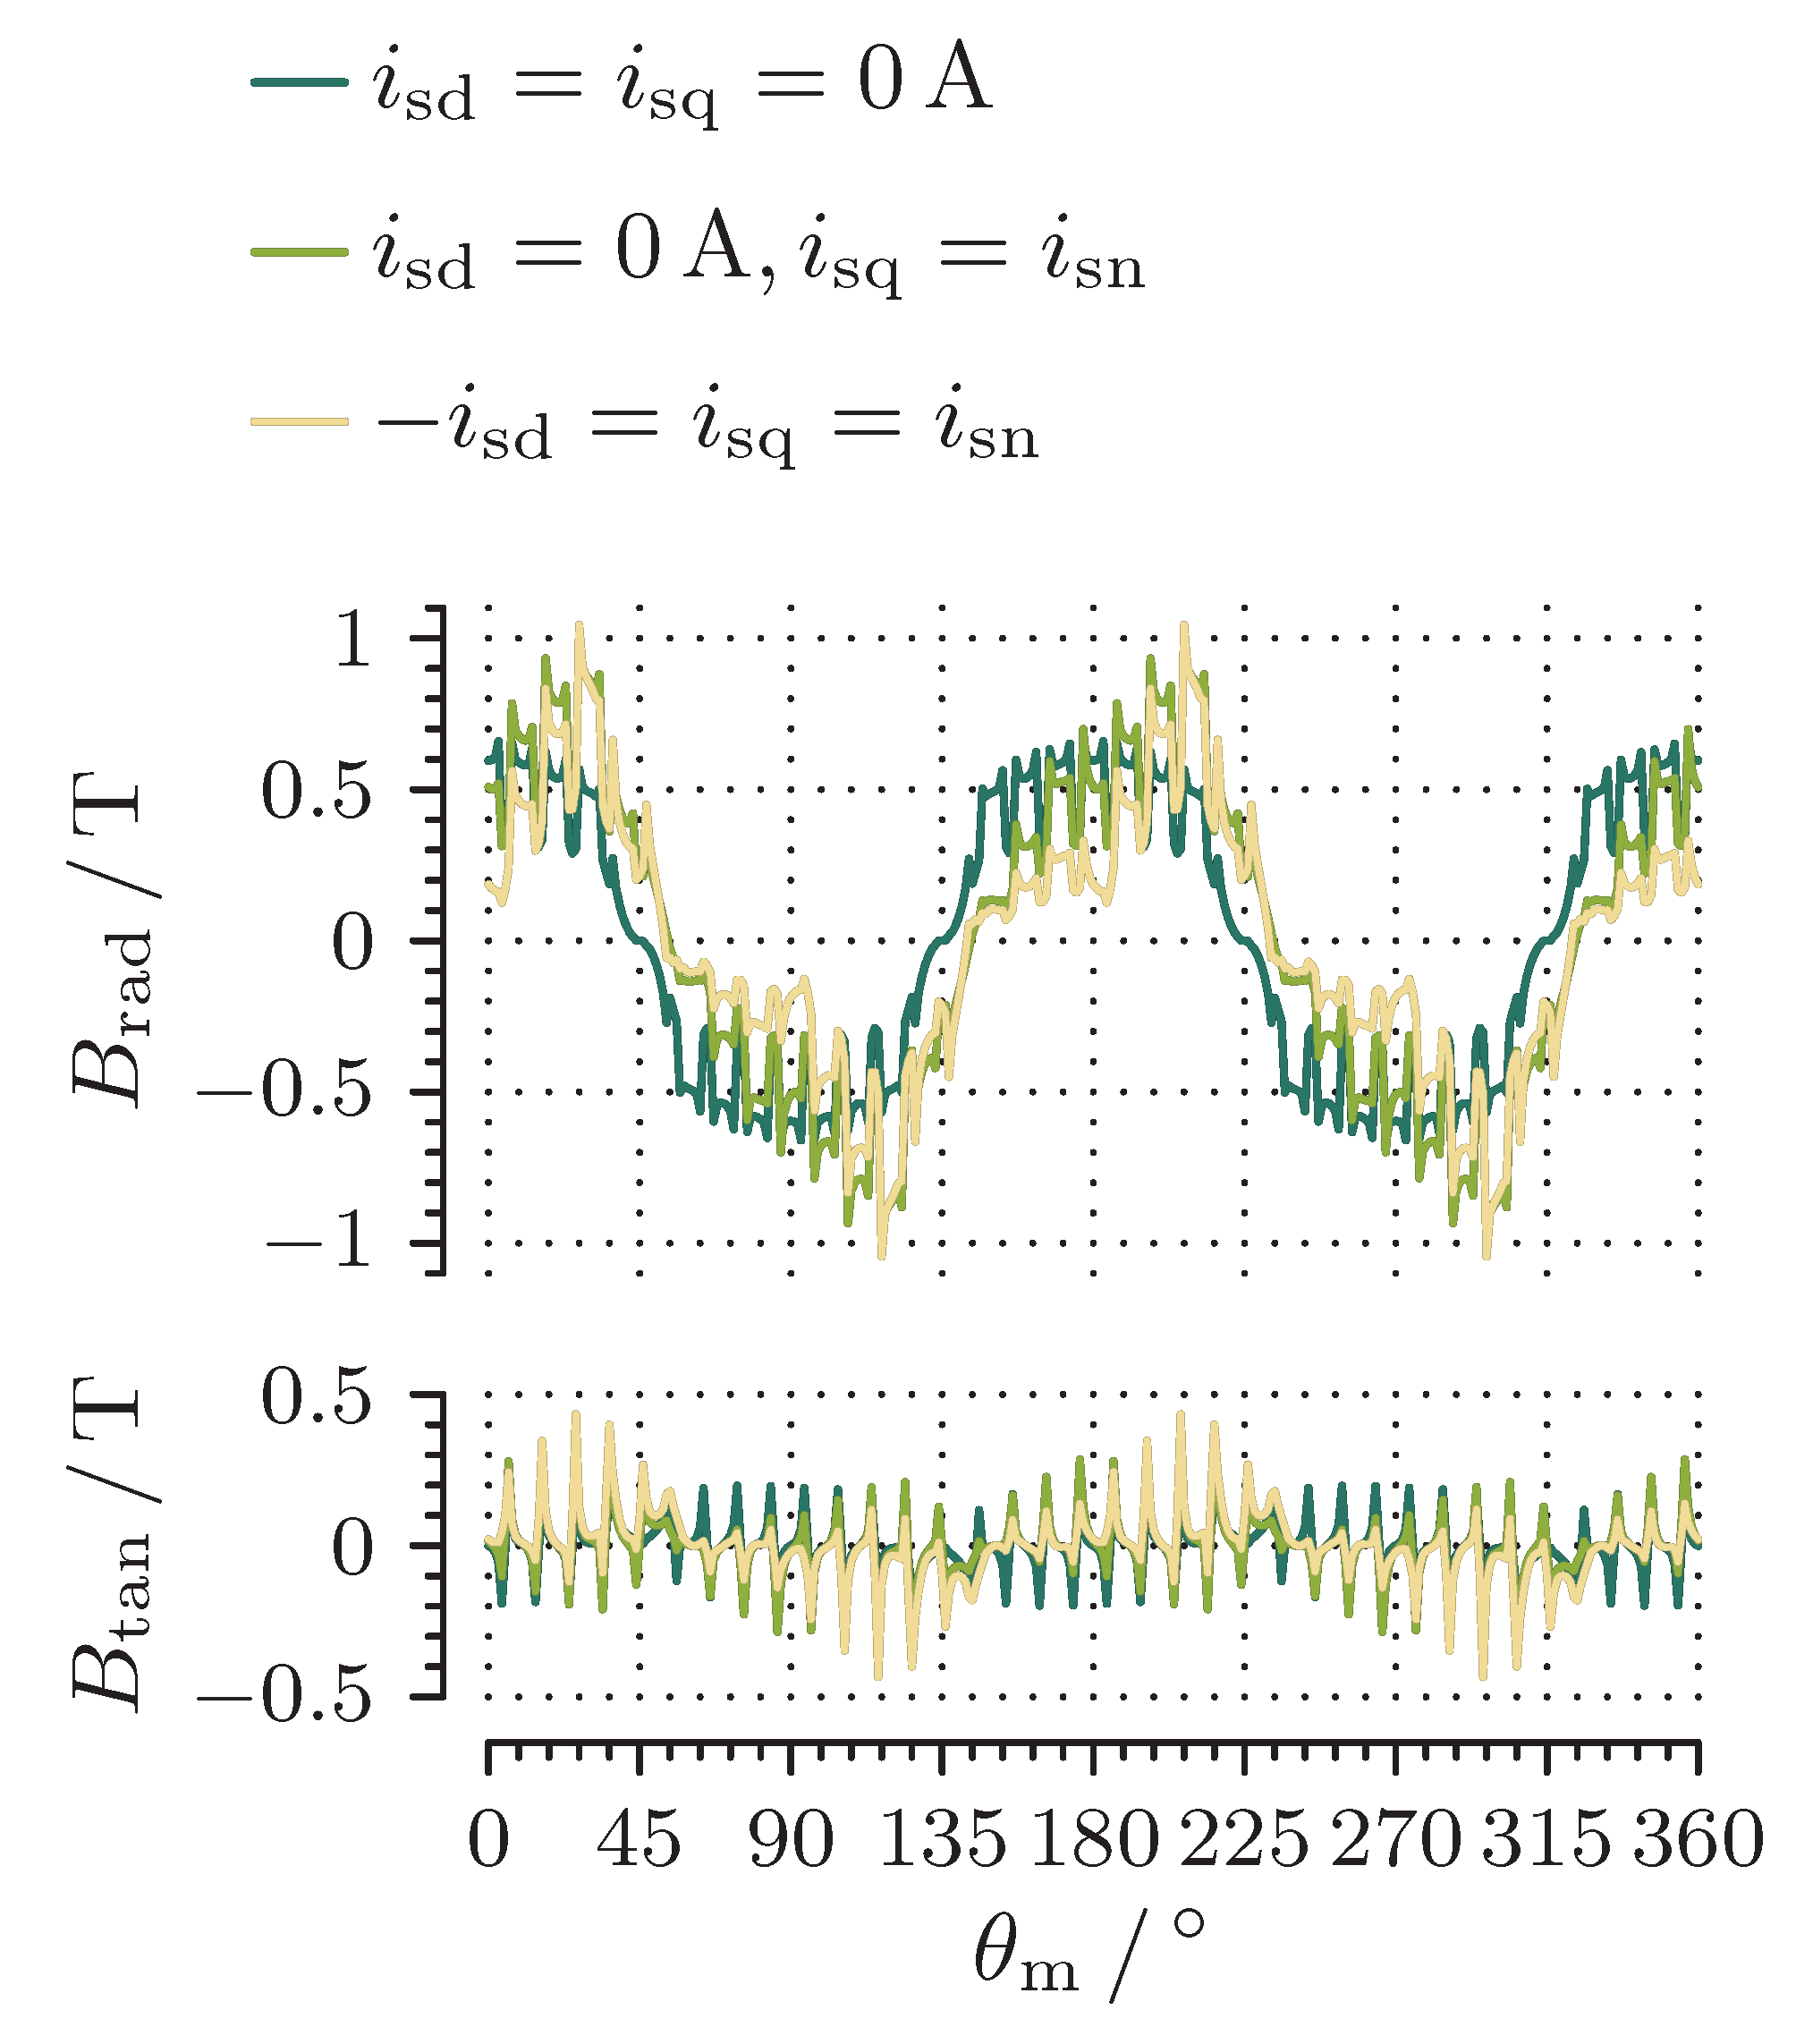
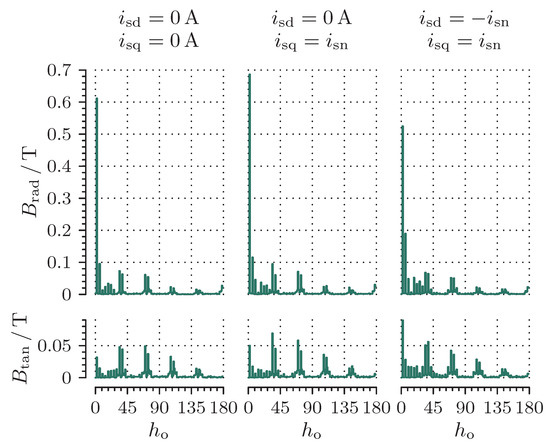
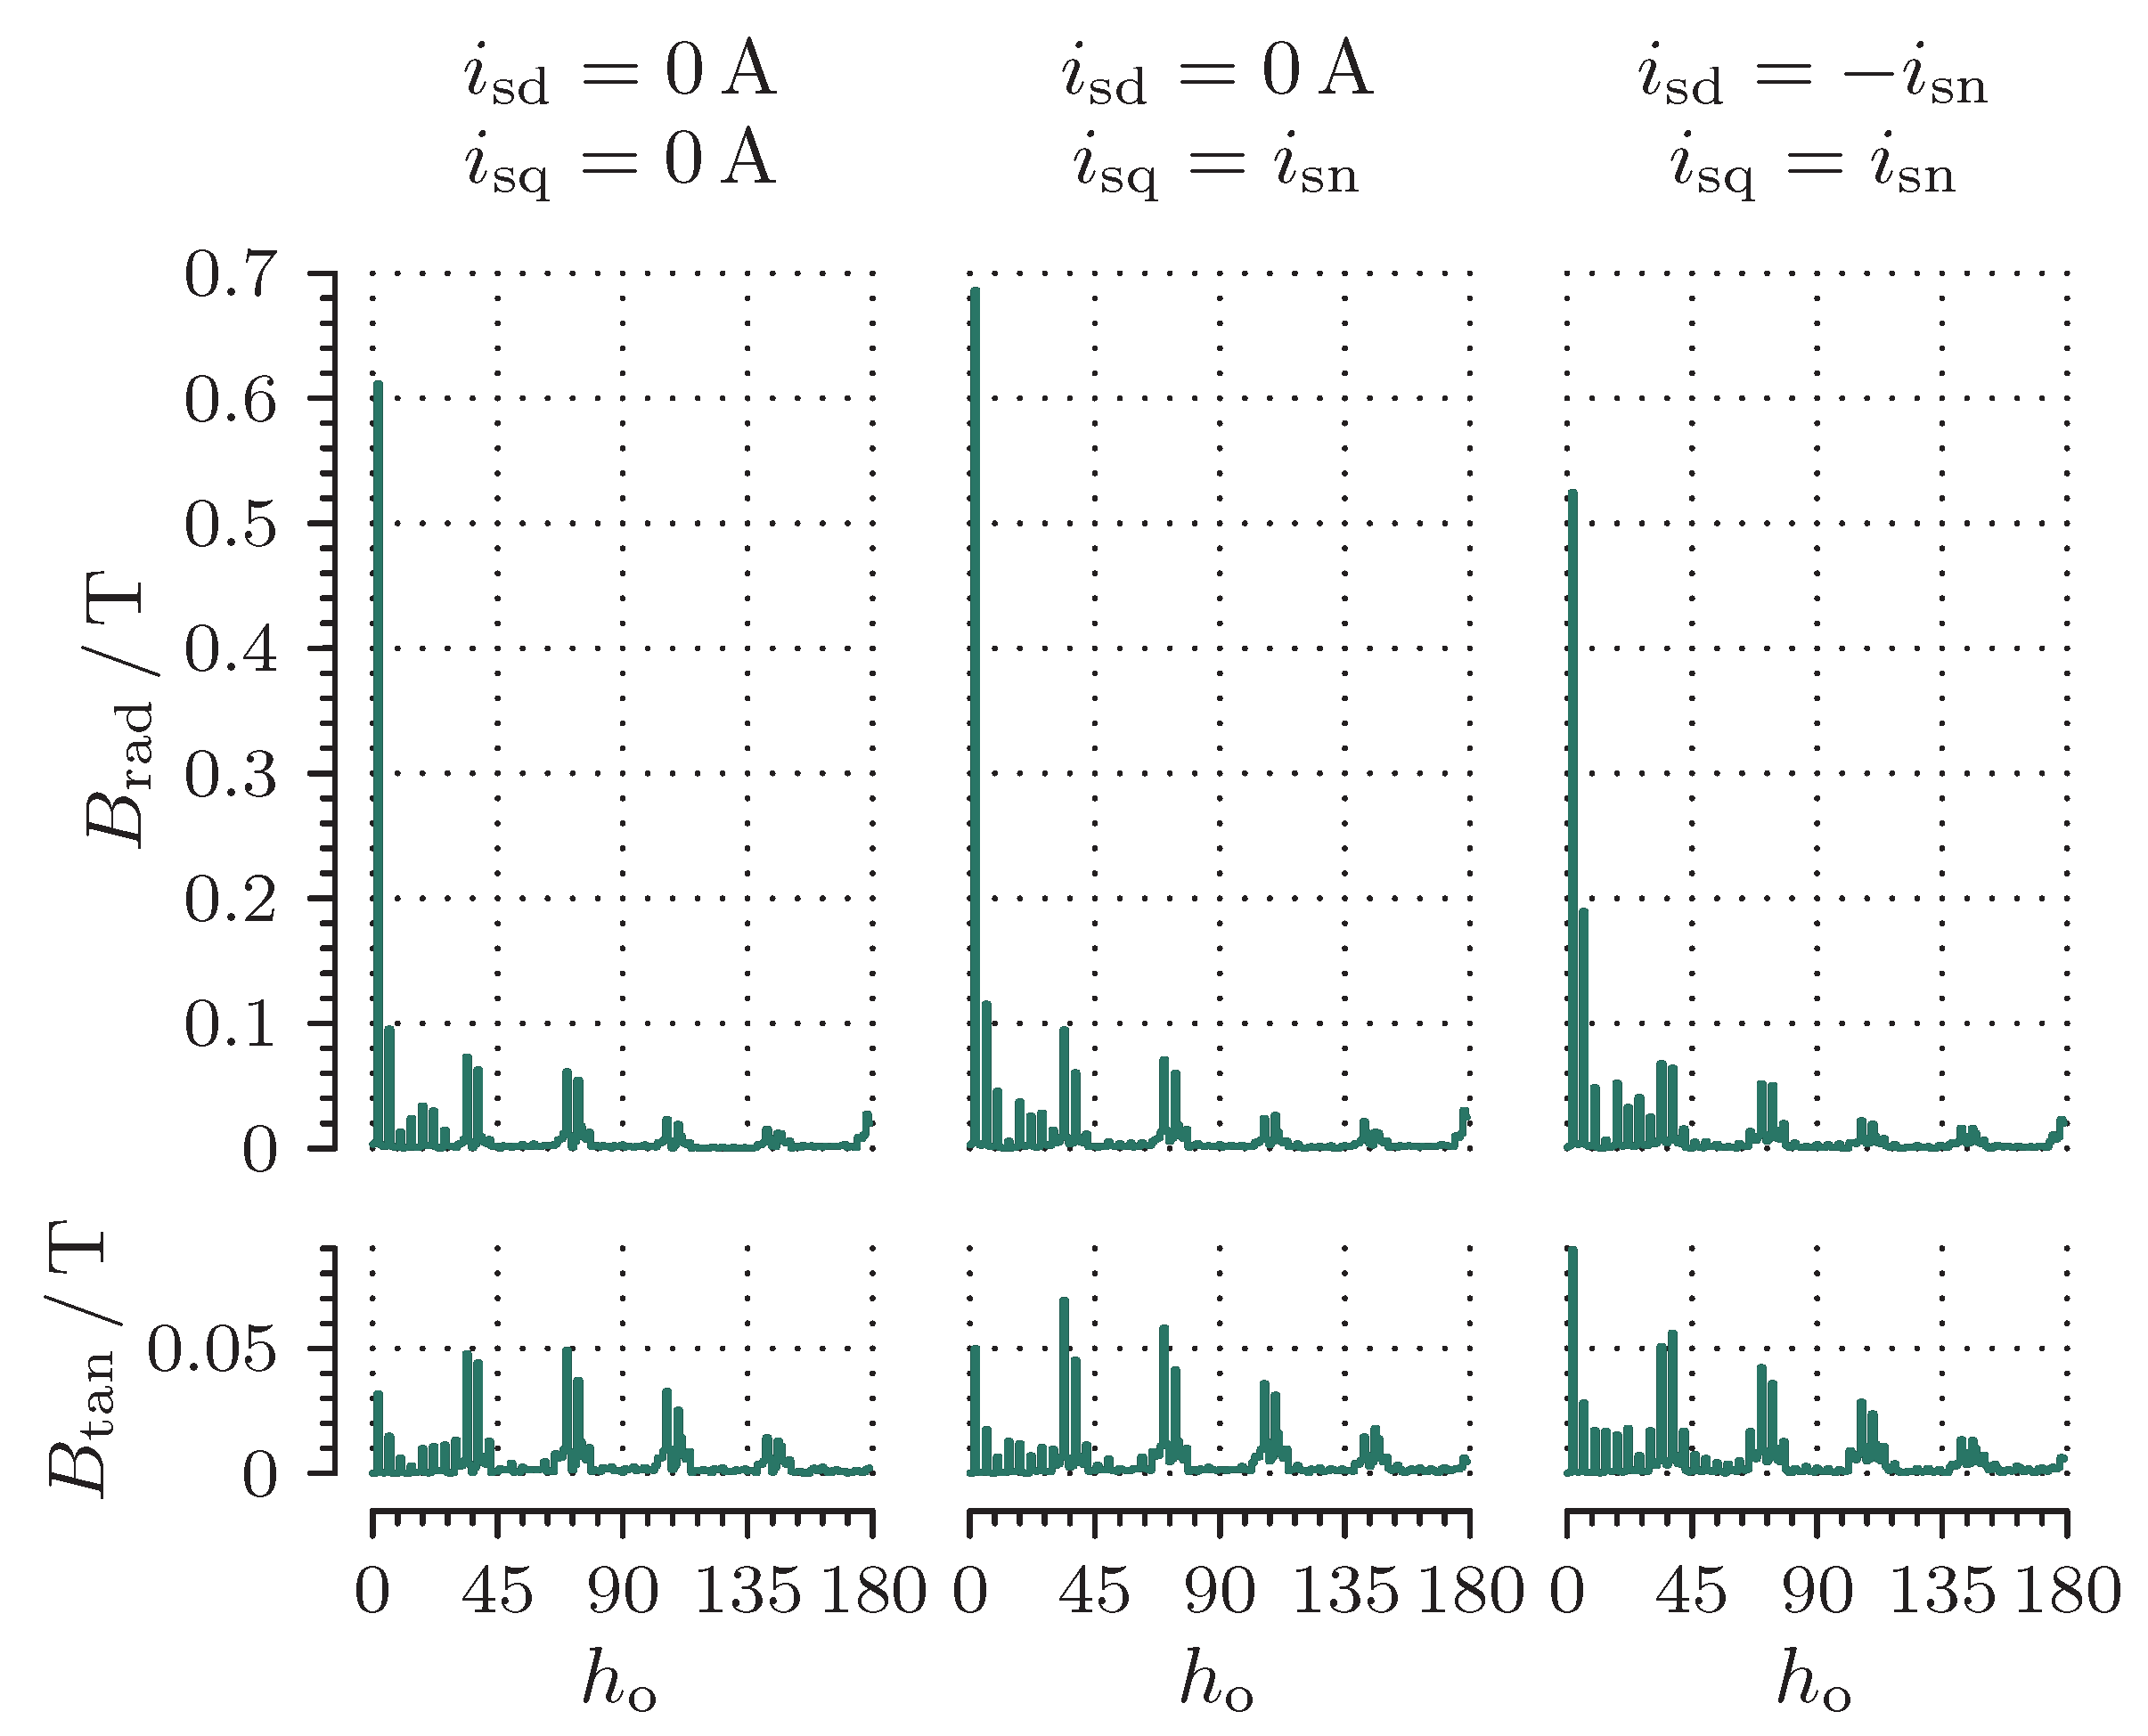
Based on (14) and (15), variations in and along at the specified evaluation points can be visualized, which for different load points is shown in Figure 2, where the direct and the quadrature components of the stator current ( and ) are expressed in terms of the nominal stator phase current (). For amounts to , while for it amounts to , and for to . The slotting effects can be seen as the peaks in both and at the beginning and the end of each pole shoe. Harmonic spectra of the waveforms of and in Figure 2 are shown in Figure 3, where denotes the harmonic order.
Figure 2.
Variations in and observed along the sleeve at for at different load points.
Figure 3.
Harmonic spectra of and for a single period of and at different load points.
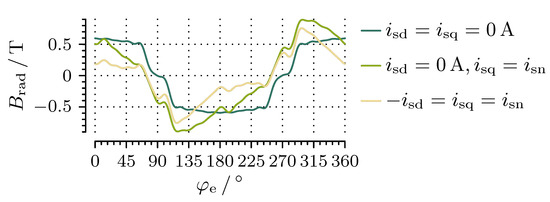
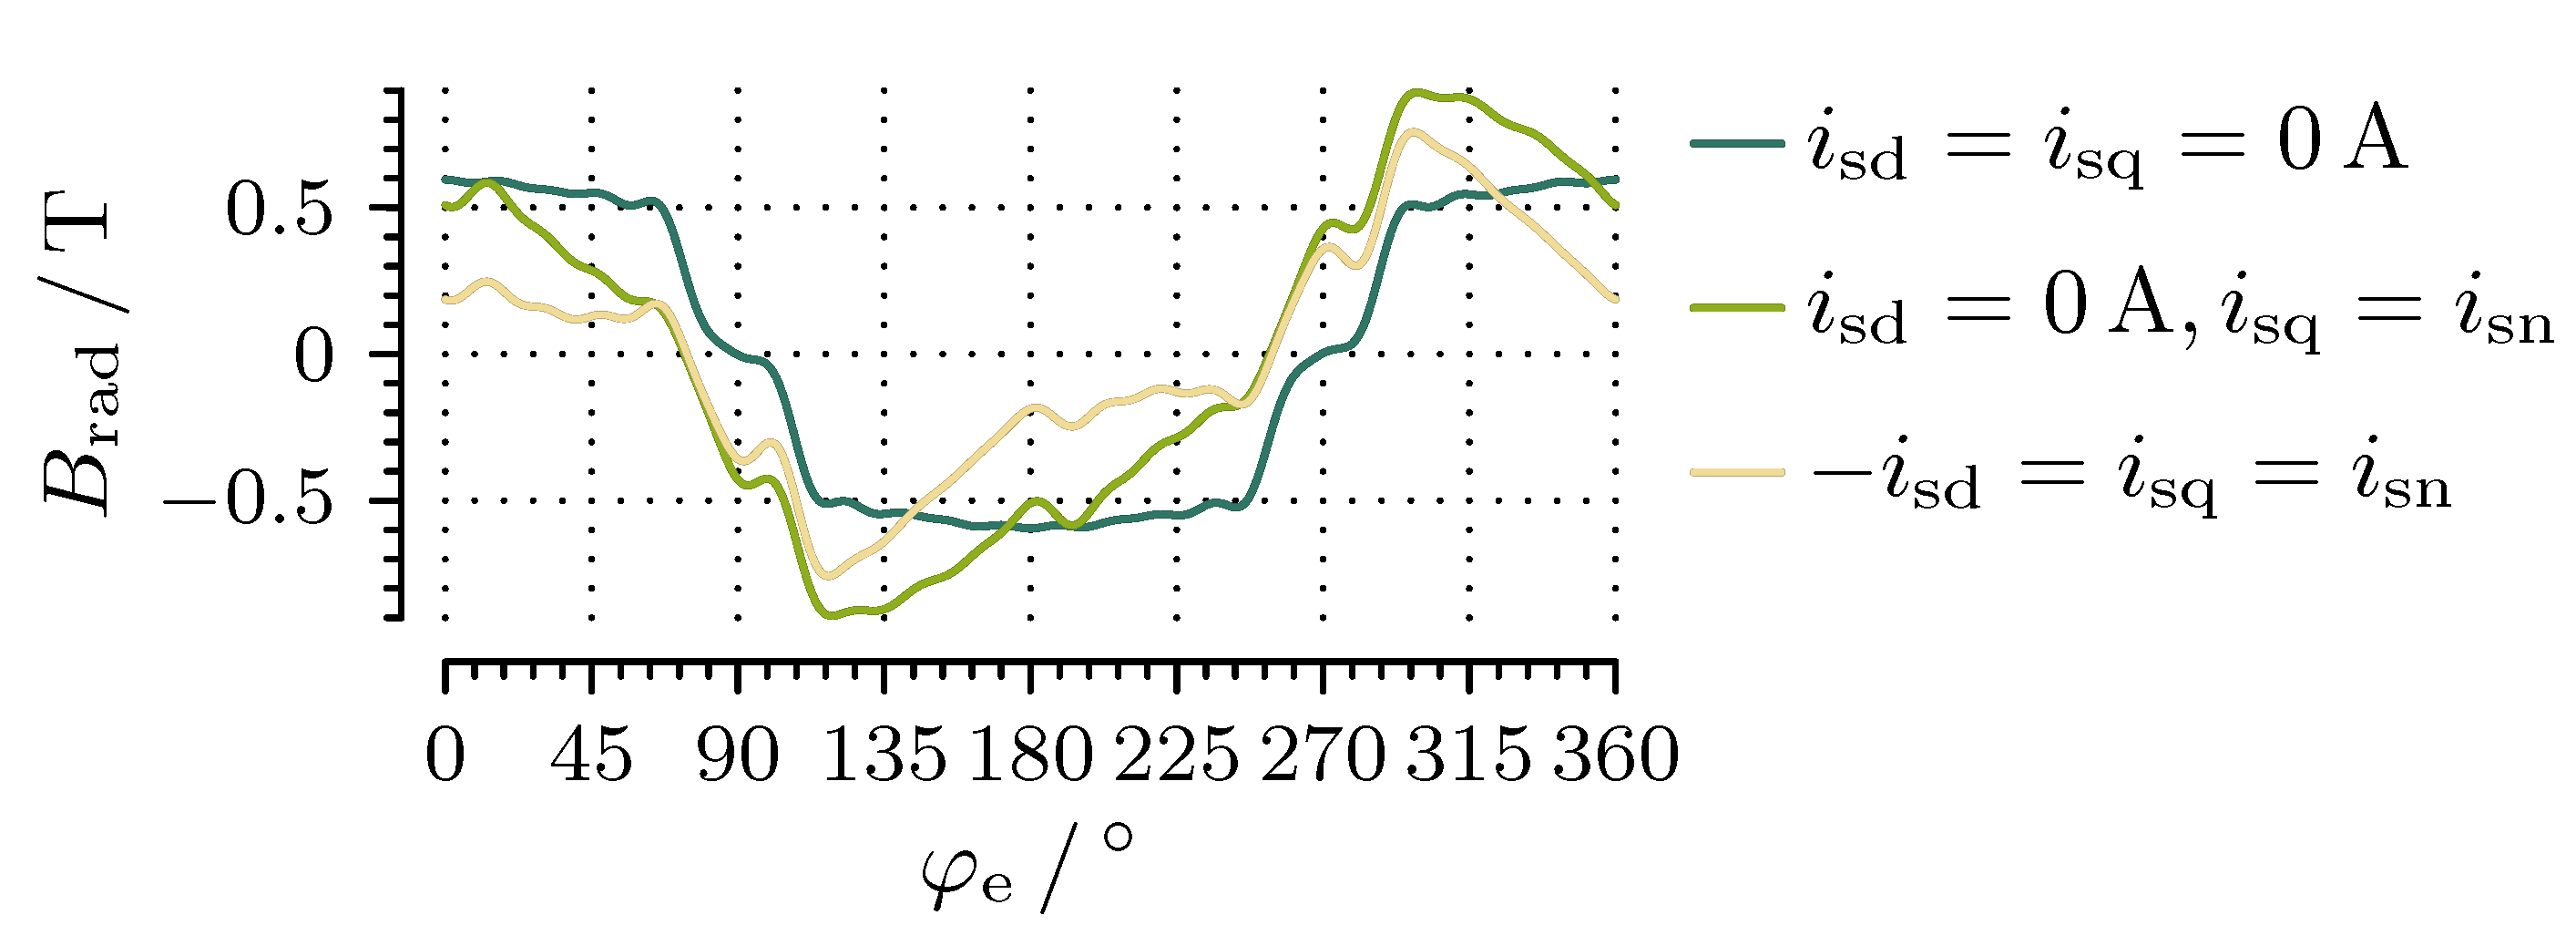
Due to the negligible radial thickness of the sleeve, is the component mainly responsible for . Hence, the partial derivative of with respect to time in (6) refers to , which needs to be observed as a function of the electrical angular position of the rotor (), as shown in Figure 4.
Figure 4.
Variations in observed by at during a single electrical rotation of the rotor at different load points.
Based on and the electrical angular speed (), which corresponds to the electrical frequency of the rotating magnetic flux density in the air gap, the partial derivative of with respect to time can be calculated as
With the total number of evaluation steps per electric period (M) the partial derivative of with respect to the rotor angle can be approximated by
For each , (16) can be written in terms of , , the mechanical speed (n) and the number of each evaluation step (m) as
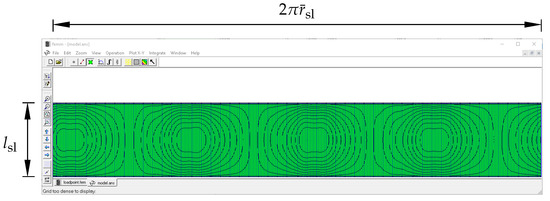
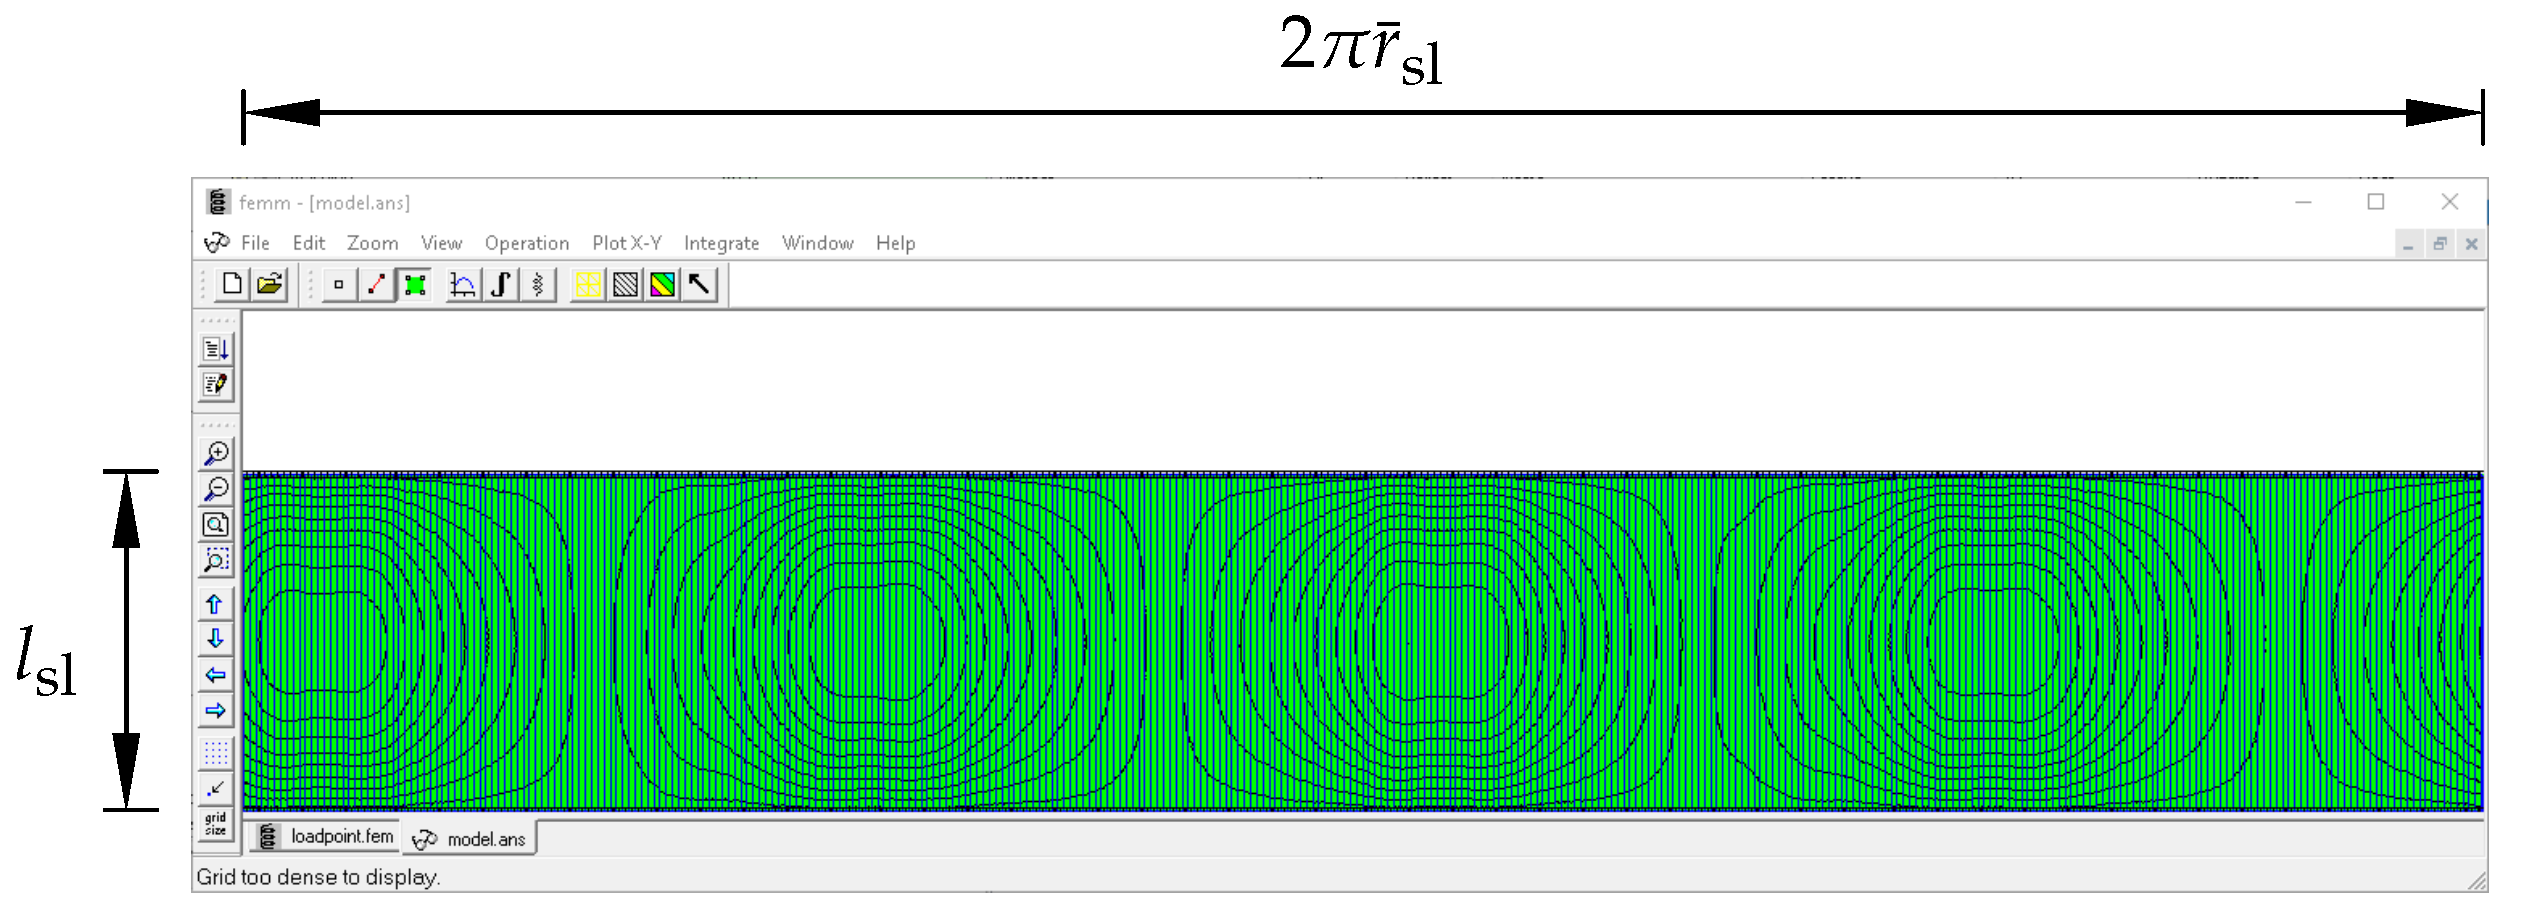
After obtaining the partial derivative of with respect to time, a new 2D magnetostatic problem in FEMM, in which the sleeve is unrolled as shown in Figure 5, is used for the calculation of .
Figure 5.
The unrolled sleeve during the calculation of in FEMM.
The sleeve is split up into small surface areas, each with the circumferential width of and the axial length of , as it can be seen in Figure 5. The sleeve can be axially positioned, and and do not have to be equal. The eddy current excitation at () for the calculation of in the new 2D magnetostatic problem in FEMM is obtained based on the corresponding magnitude of () in the surface area (A) between two neighboring evaluation points according to (6) and (18) as
Finally, the average value of that represents the average 2D magnetostatic solution of FEMM () is obtained from the value of at each evaluation step during a full electric period () as
where each is obtained according to (12).
4. Simulation Results
Simulations were performed for (evaluation points) and (evaluation steps), which in the presented case seemed like a good tradeoff between the accuracy and the calculation speed. The results of for of , , and , at the same load points for which is presented in Figure 2 and Figure 4 are listed in Table 3. In Table 3 it can be noticed that using only increases , while negative values of reduce . The latter implies that topologies with embedded magnets, which are suitable for field weakening to use the reluctance torque, might be better suited for these applications.
Table 3.
Simulation results of at .
4.1. Verification of 2D Simulation Results by 3D Simulations
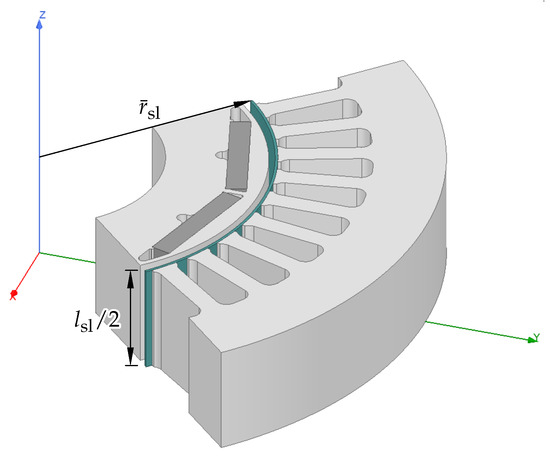
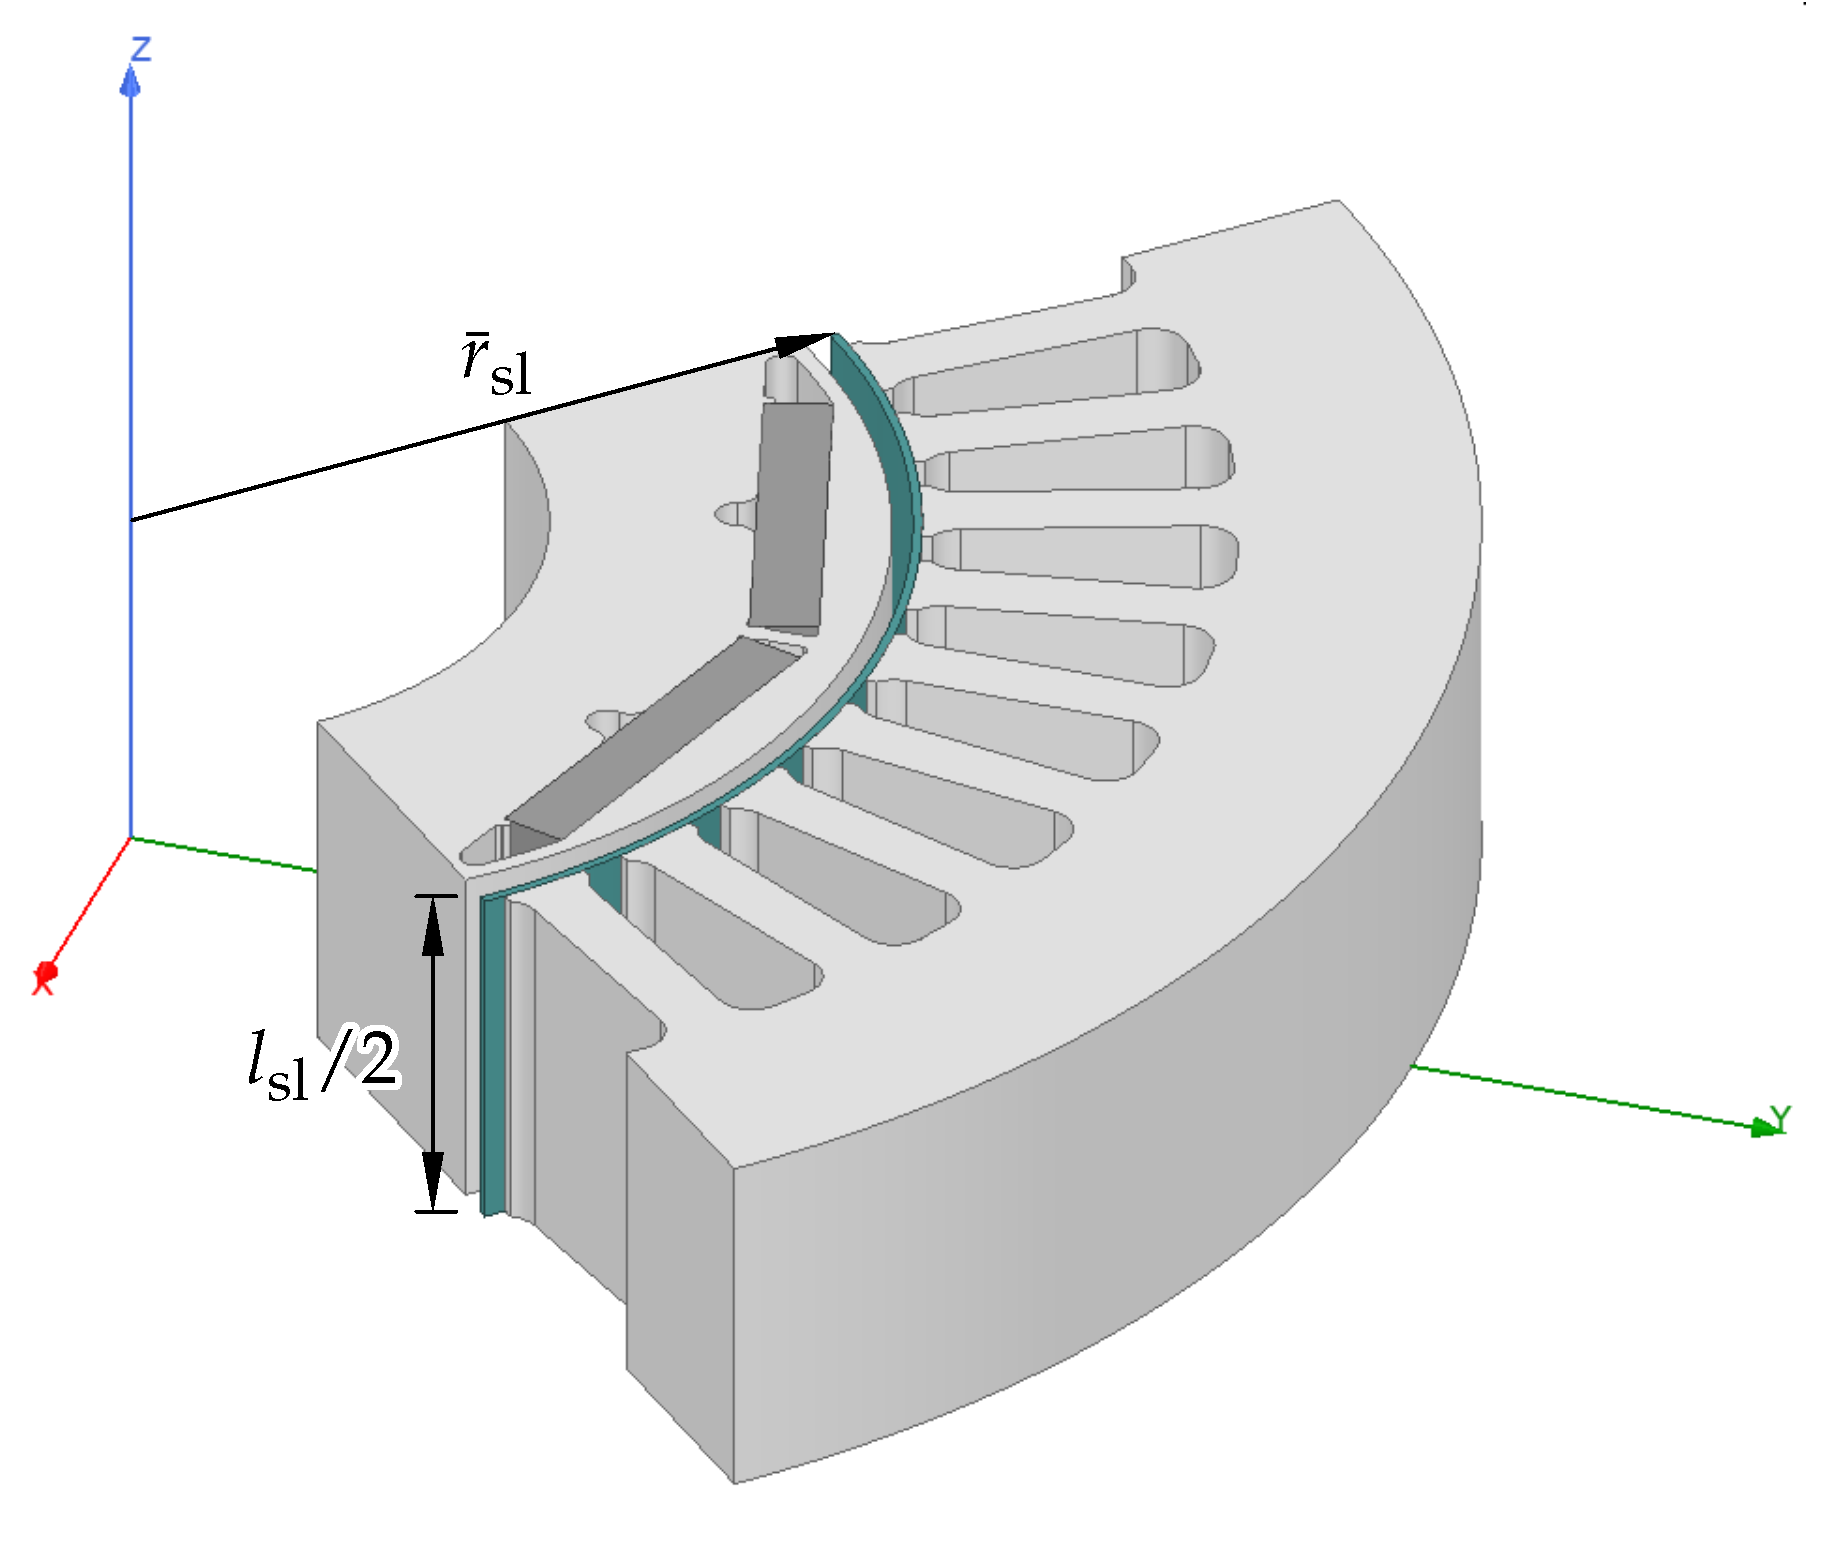
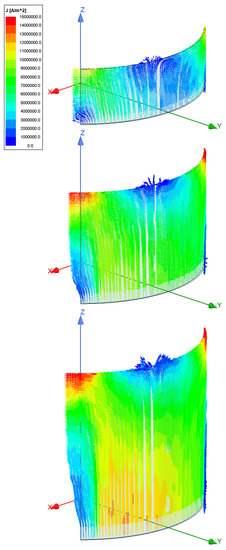
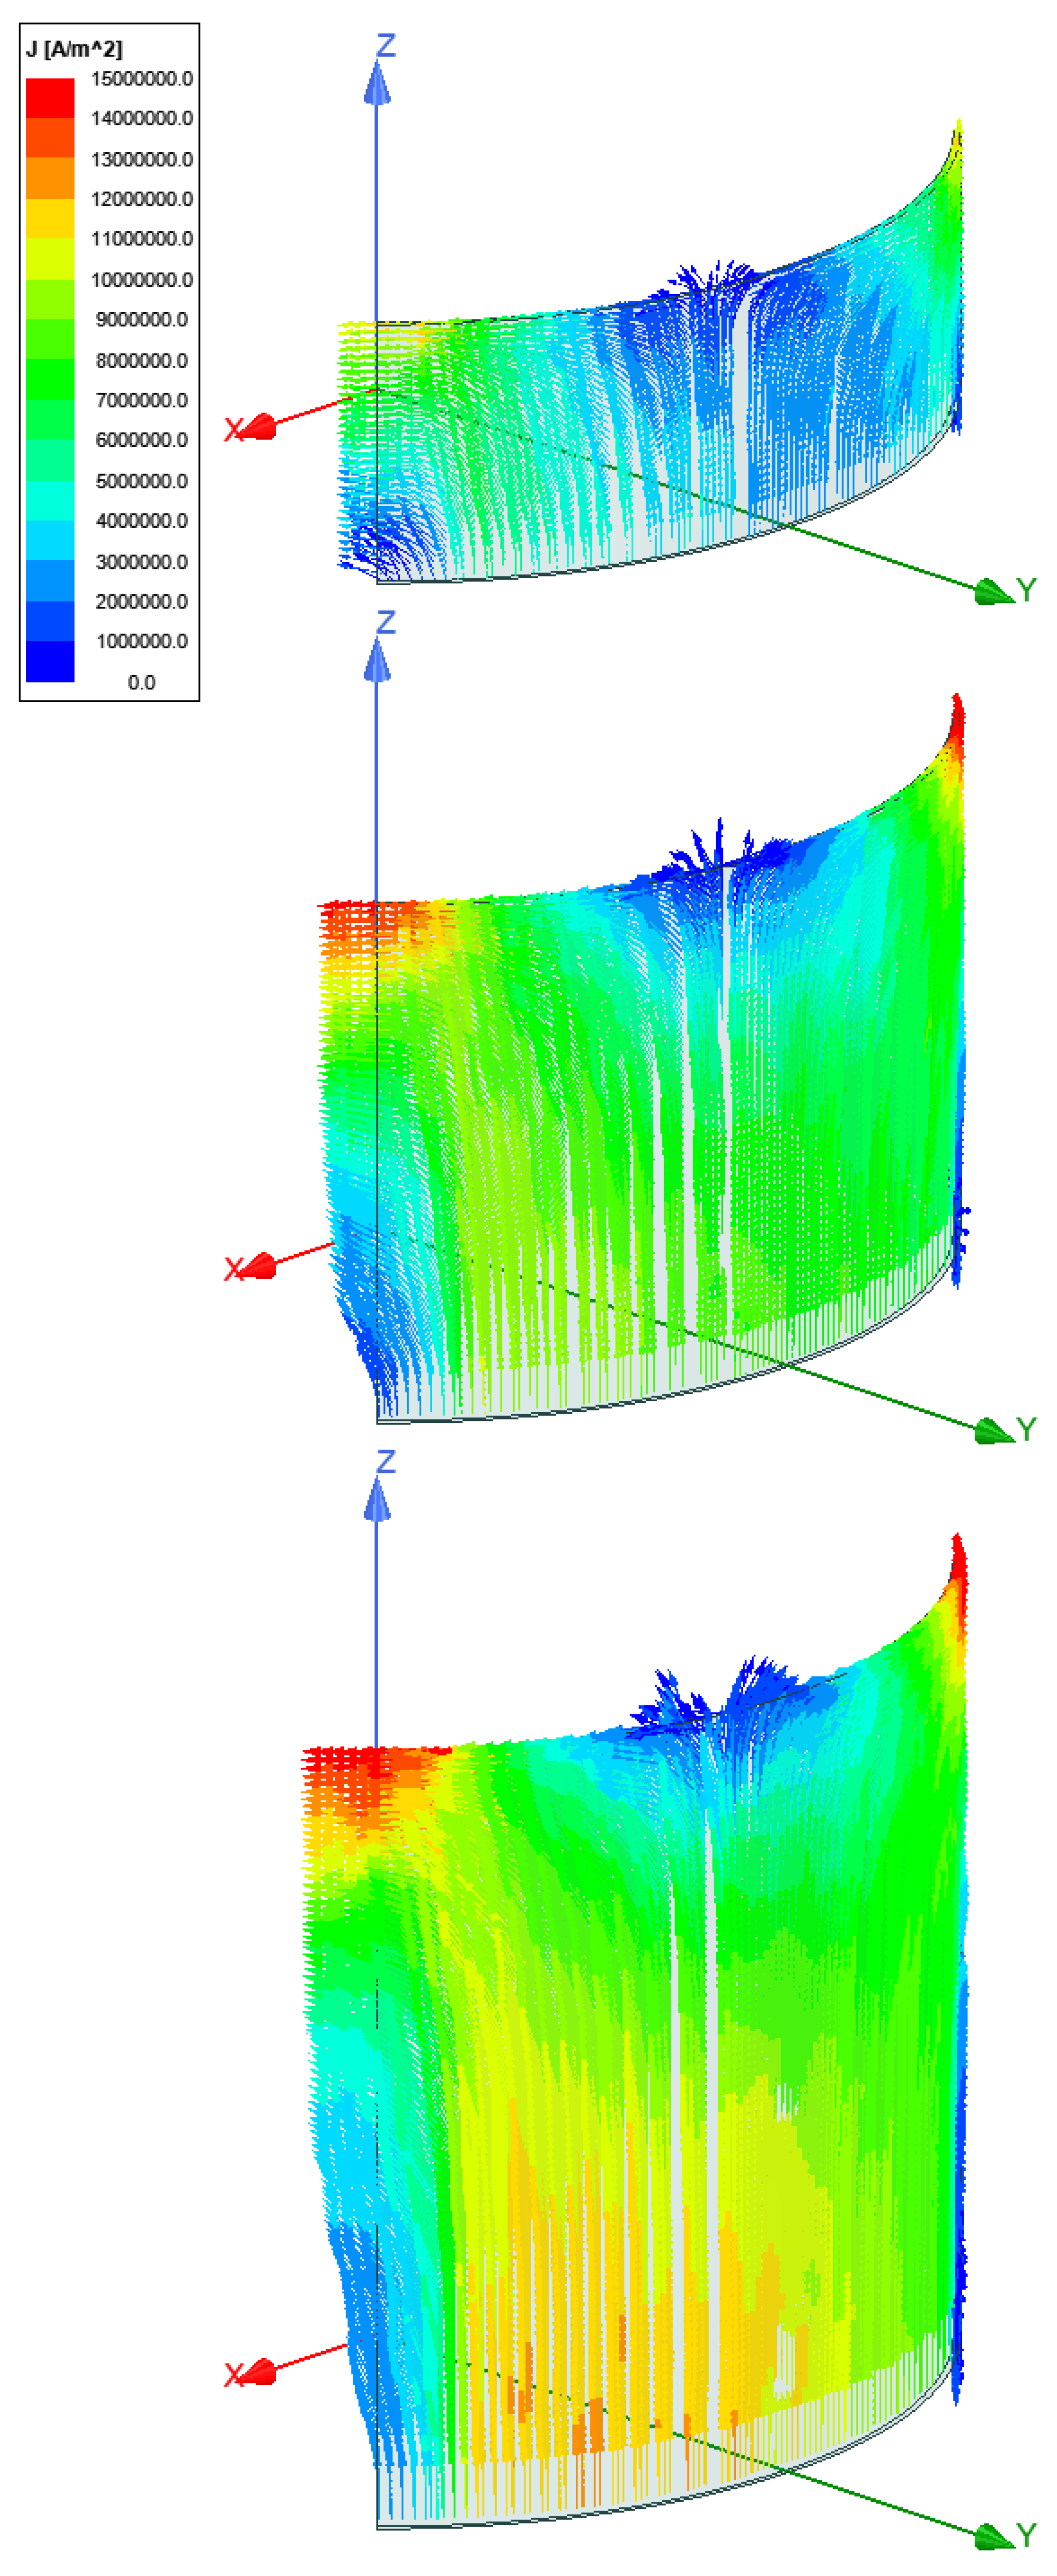
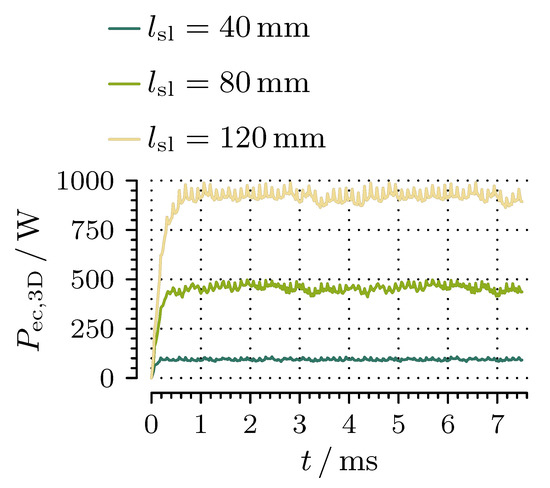
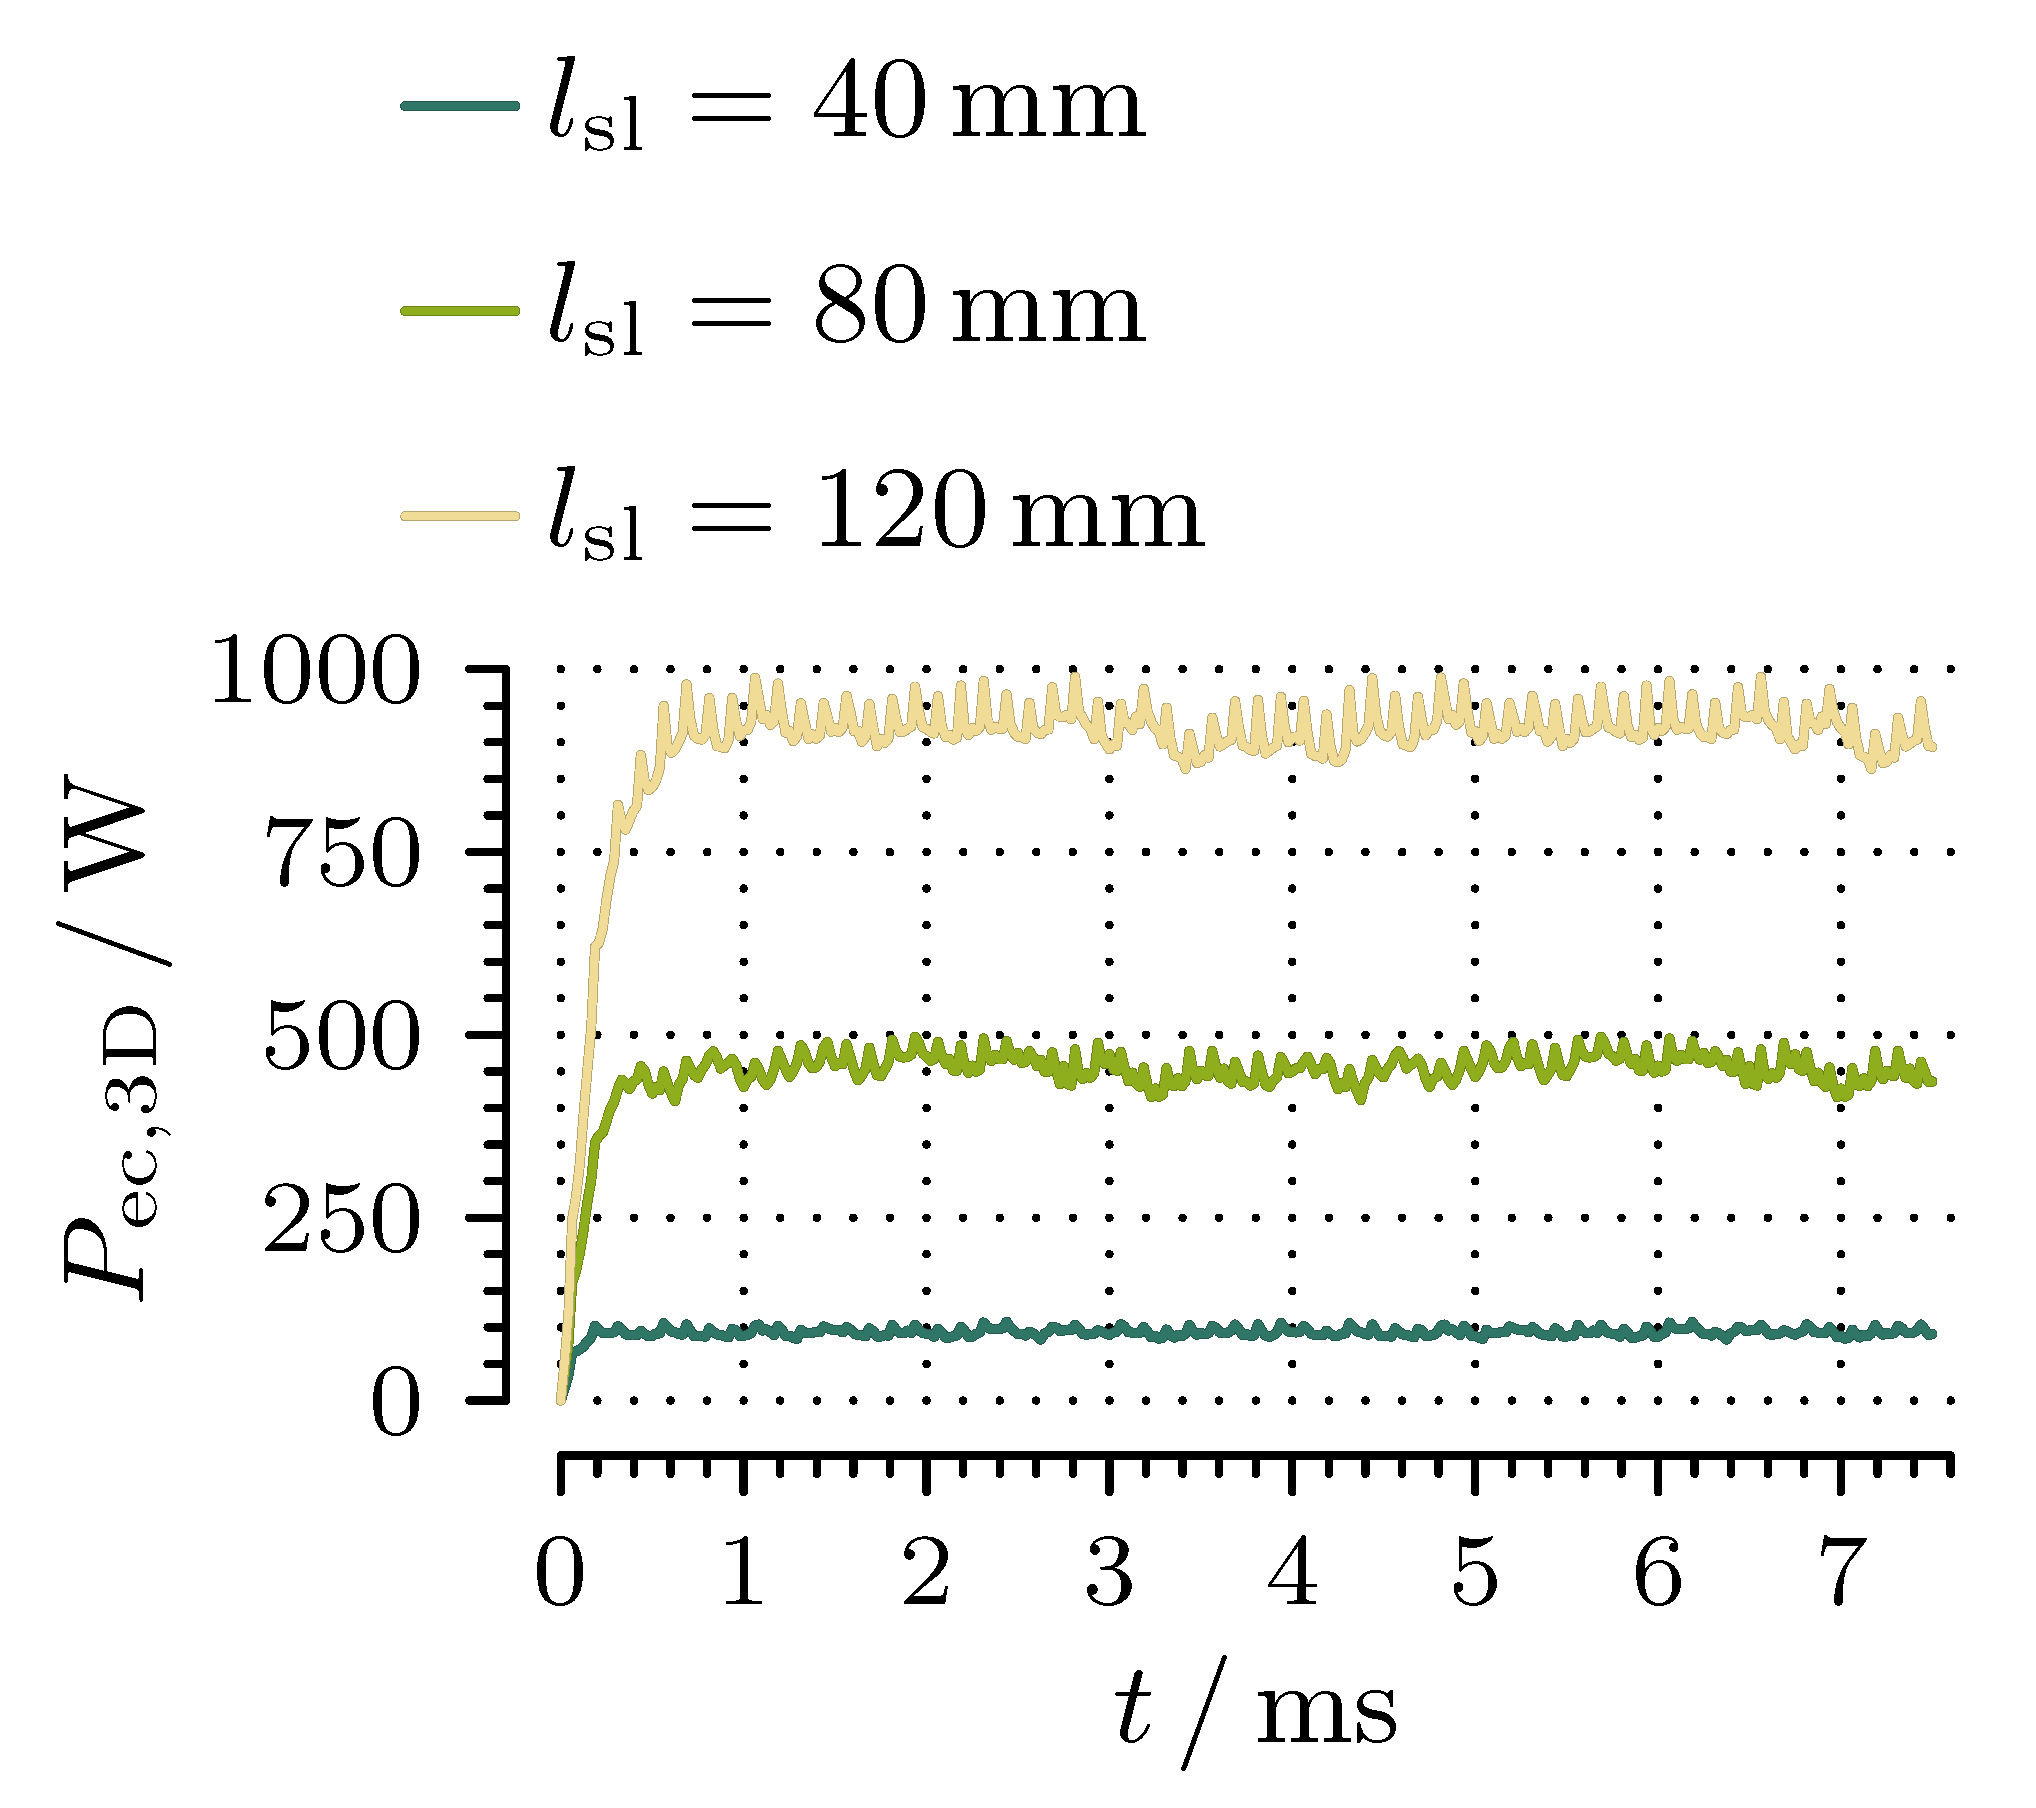
For a validation of the 2D simulation results obtained by the proposed method, the 2D model from SyMSpace was implemented as a 3D model in Ansys Electronics Desktop 2019 R3 (AED) [12] and used for 3D FEM transient simulations to obtain reference values of . Since it is sufficient to observe the no-load case, the AED model was simulated without the stator windings by using both tangential and axial symmetry. That means that a single pole over a half of the axial length of the machine was simulated, as shown for in Figure 6, to minimize the computation time. The distribution of in the sleeve (colored in teal in Figure 6) is shown for different values of in Figure 7. The transient 3D FEM simulation results of () obtained by AED at for of , , and , are shown in Figure 8. To avoid the influence of the transient character of in Figure 8, the mean average value of () over the last half of the electrical period of each characteristic was taken as the representative value of each 3D simulation. A comparison of the no-load results of listed in Table 3 with is given in Table 4, where the average magnitude of in () was obtained from AED, while the relative 2D percent error in () was calculated as
Figure 6.
The 3D AED model used for the calculation of in the sleeve.
Figure 7.
The distribution of in the sleeve in AED at for three different values of .
Figure 8.
Transient no-load simulation results of obtained by AED during a single electrical period at for three different values of .
Table 4.
A comparison of 2D and 3D no-load simulation results at .
The values of listed in Table 4 are smaller than because the transient solver in AED takes into account the influence of the magnetic field created by the induced eddy currents on the excitation field. From Table 4 can also be seen that by doubling , increases by about , which in this case explains the quadratic behavior, since is defined by (11) where according to the microscopic form of Ohm’s law .
4.2. Valid Frequency Range of the Proposed Method
The application of the proposed method is limited due to the neglect of the attenuation of the changing excitation field caused by the magnetic field created by the induced eddy currents that opposes the changing excitation field. To demonstrate the frequency limitation and were calculated for of at different frequencies in the range from to and presented in Figure 9.
Figure 9.
A comparison of and in the frequency range from to in the worst of the three analyzed cases regarding in which is .
In Figure 9 it can be seen that the magnetic field created by the induced eddy currents in the sleeve begins to attenuate the changing excitation field more significantly as the frequency increases above , which in turn reduces .
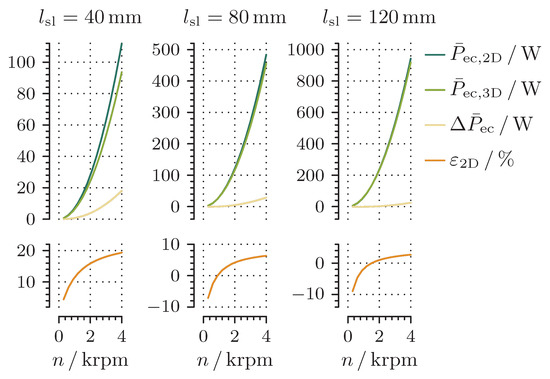
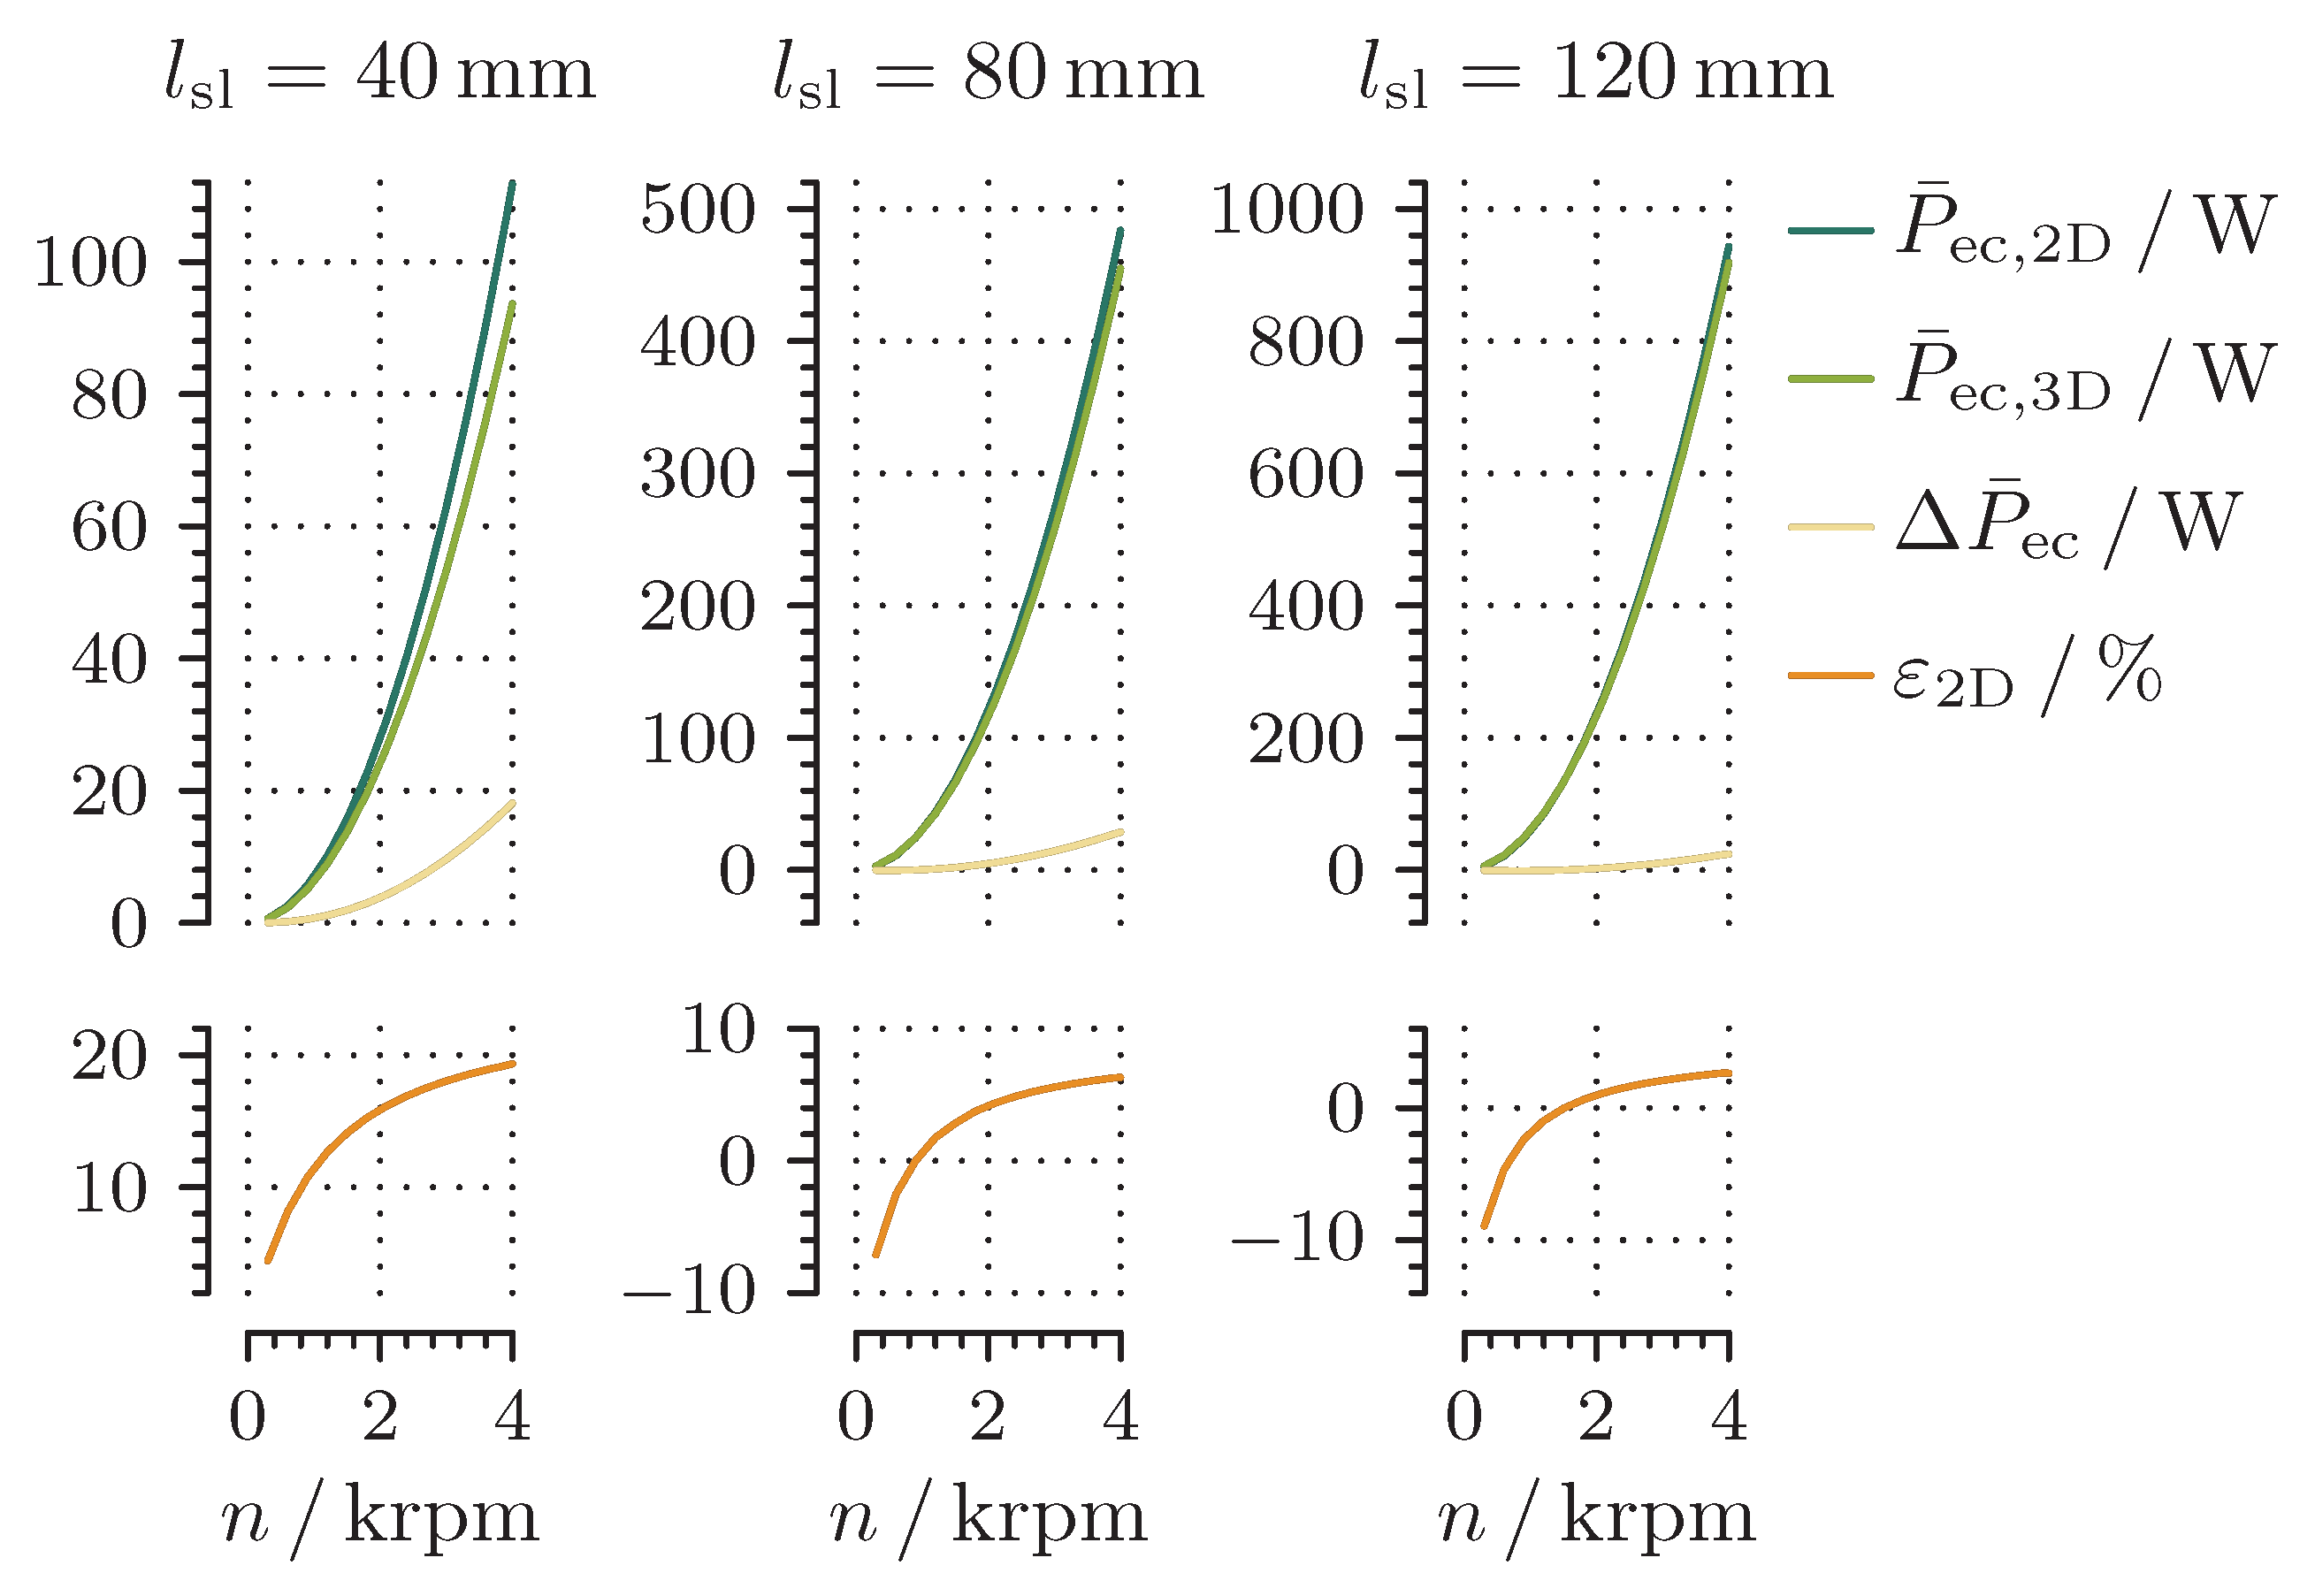
The frequency range presented in Figure 9 corresponds in this case to the range from to , which is significantly above specified in Table 2 as well as the upper limit of typical industrial applications. Hence, for a meaningful comparison, and together with their difference () and are shown in Figure 10 in the range from to for of , , and .
Figure 10.
, , , and in the speed range from to for of , , and .
From the presented results it can be seen that the discrepancies between and increase with a decrease in . The main cause of that is presumably the inability of the 2D FEM solver to calculate the axial stray magnetic field.
The preference for axially long sleeves in 2D calculations of is also implied by the axial-to-radial ratio () presented per harmonic () in [13] as
which is a part of a relatively accurate analytical description of () for all harmonics of presented in the form of
where the overhang correction factor () is defined in terms of and the overhang factor () as
in which defines the relationship between and as
From (23) it can be seen that increases with the square of and that often cannot be reduced. More importantly, increases with the cube of , what should be considered in the design.
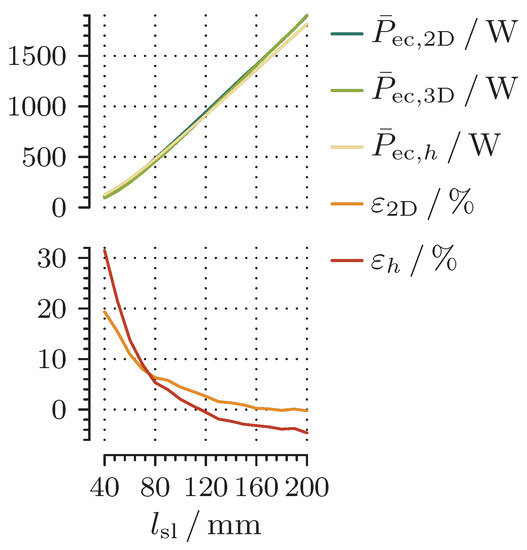
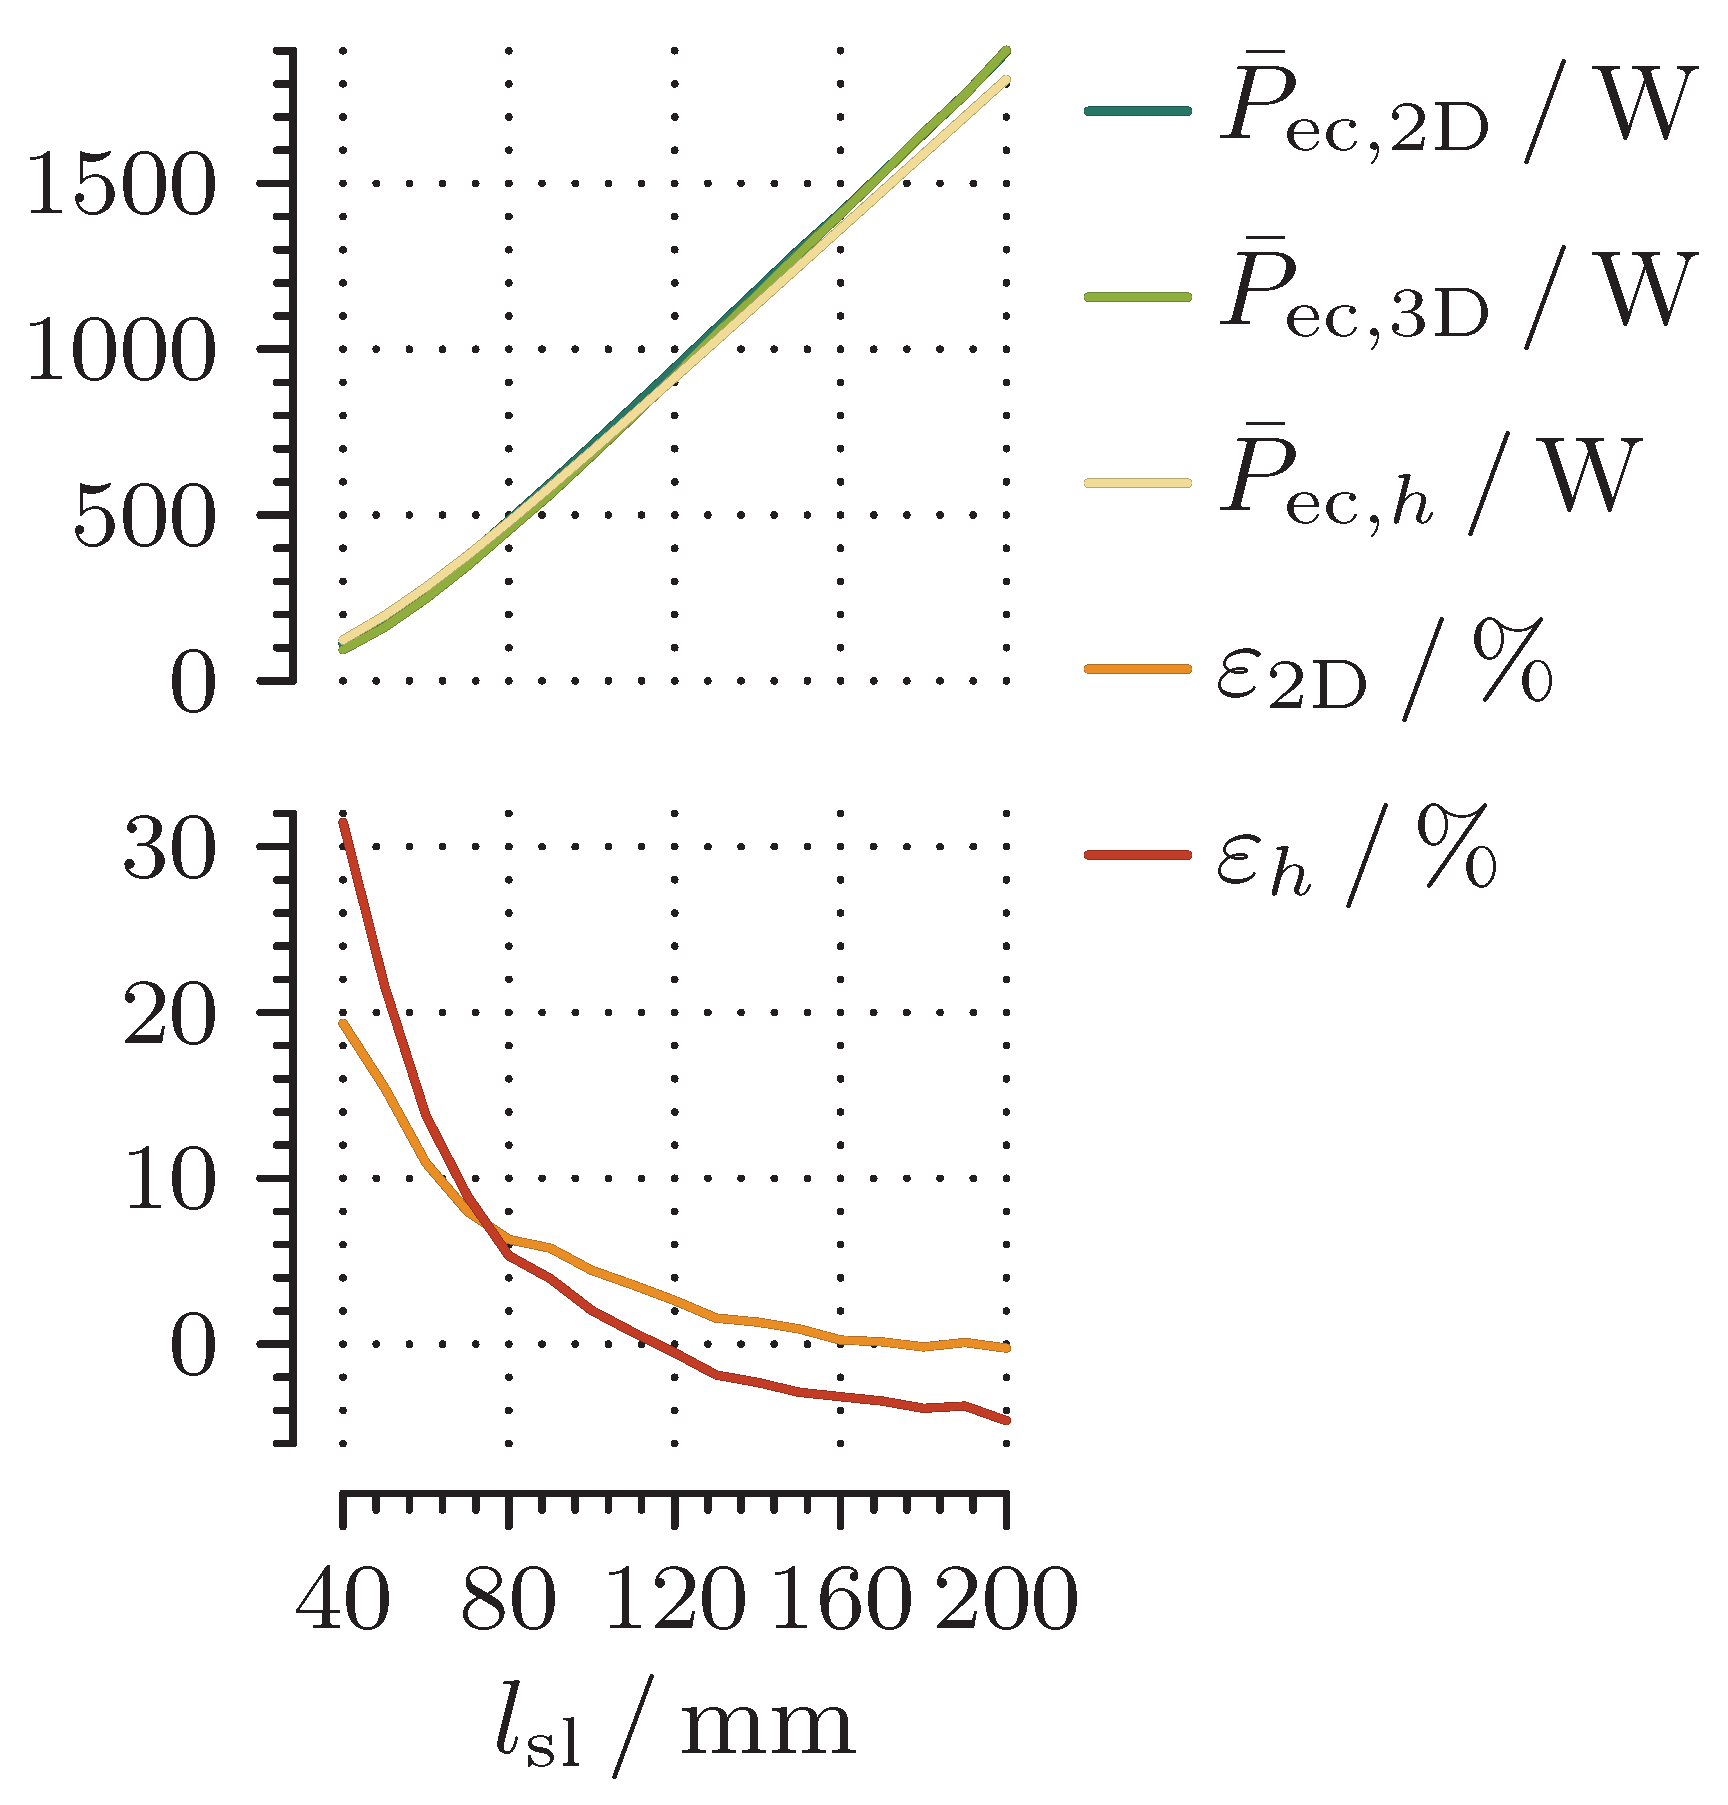
An additional comparison of no-load simulation results of , , and obtained by (23) from the harmonic spectra of shown in Figure 3 is shown in Figure 11 for in the range from to at together with and the relative analytical percent error in (). The lack of smoothness in and in Figure 11 is primarily caused by the coarseness of the mesh of the 3D FEM solver that creates noise in the simulation results, which can also be seen in Figure 8. Nevertheless, it is clearly visible that the relative error decreases with increasing sleeve length due to the decreasing impact of the neglected end effects.
Figure 11.
A no-load comparison of , , and for in the range from to with and at .
From the tendency of and it can be seen that the discrepancies between and for values of smaller than approximately are greater than those between and in the same range. For greater than approximately , the share of the axial stray magnetic field in the total excitation field is relatively small, which results in the absolute value of below .
5. Conclusions
This paper has successfully demonstrated that a 2D FEA solver for magnetostatic problems can be used for eddy current loss calculation. The method is based on the similarity between the differential forms of Faraday’s law of induction and Ampère’s circuital law for magnetostatics. By reassigning the field quantities, the numerical solution of refers to . Therefore can be evaluated efficiently for a thin sleeve situated in the air gap of a sealless pump.
According to the simulation results listed in Table 3, using only increases in the sleeve primarily due to the increase in the fundamental harmonic but also because of the increased harmonic content of introduced by the stator magnetic flux density, as it can be seen in Figure 3. In contrast, field weakening reduces in the sleeve due to the drop in the fundamental harmonic of mainly produced by the rotor magnets, which can as well be seen in Figure 3. This also suggests that rotor topologies with embedded magnets that exhibit reluctance torque might be better suited for these applications when a control strategy that uses field weakening is being employed. However, increasing and increases the harmonic content of , which can be seen in Figure 3.
For the frequency range of typical industrial applications in which our proposed method is intended to be applied, the reaction field can be neglected. Furthermore, it is derived in (12) and (23) that the relationship between eddy current loss and sleeve conductivity is linear. Combined with the fact that the reaction field is negligible it can be concluded that the eddy current loss increases linear with the sleeve conductivity.
The comparison of 2D and 3D no-load simulation results listed in Table 4 shows that increases as decreases. That is mainly caused by the inability of the 2D FEM solver to correctly calculate the share of the axial stray magnetic field of the sleeve in the total excitation field. For smaller values of these end effects have a higher fraction relative to the actual total excitation field, thereby making seemingly higher. From (23) it can also be seen that increases with the square of and and with the cube of . Since and may not be easily reduced, is an important parameter for an efficient pump design.
Author Contributions
Conceptualization, M.P., G.J., B.W., T.S. (Thomas Stallinger); methodology, B.W., G.J., M.P., T.S. (Thomas Stallinger); software, T.S. (Tomislav Strinić), B.W., G.J.; validation, T.S. (Tomislav Strinić), T.S. (Thomas Stallinger); formal analysis, T.S. (Tomislav Strinić); investigation, T.S. (Thomas Stallinger); resources, J.F.; data curation, T.S. (Tomislav Strinić); writing—original draft preparation, T.S. (Tomislav Strinić), G.J.; writing—review and editing, B.W.; project administration, G.J., T.S. (Thomas Stallinger). All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the COMET-K2 “Center for Symbiotic Mechatronics” of the Linz Center of Mechatronics (LCM) funded by the Austrian Federal Government and the federal state of Upper Austria.
Conflicts of Interest
The authors declare no conflict of interest. The funders had no role in the design of the study; in the collection, analyses, or interpretation of data; in the writing of the manuscript, or in the decision to publish the results.
References
- Yu, Q.; Laudensack, C.; Gerling, D. Analysis and Loss Reduction of a Canned Switched Reluctance Drive from the Windings Perspective. In Proceedings of the IEEE 7th International Power Electronics and Motion Control Conference, Harbin, China, 2–5 June 2012; pp. 1095–1099. [Google Scholar]
- Uneyama, D.; Akiyama, Y.; Manome, S.; Naruta, T. The Proposal of Can Loss Estimation Method of Canned Motor. In Proceedings of the 2007 International Conference on Electrical Machines and Systems (ICEMS), Seoul, Korea, 8–11 October 2007; pp. 882–885. [Google Scholar]
- Gieras, J.F.; Koenig, A.C.; Vanek, L.D. Calculation of Eddy Current Losses in Conductive Sleeves of Synchronous Machines. In Proceedings of the 18th International Conference on Electrical Machines, Vilamoura, Portugal, 6–9 September 2008; pp. 1–4. [Google Scholar]
- Yu, Q.; Wang, X.; Cheng, Y.; Tian, L. Analysis of Eddy Current and Loss of a Novel Canned Switched Reluctance Machine. IEEE Trans. Ind. Electron. 2018, 65, 7640–7647. [Google Scholar] [CrossRef] [Scilit]
- Burkhardt, Y.; Huth, G.; Urschel, S. Eddy Current Losses in PM Canned Motors. In Proceedings of the XIX International Conference on Electrical Machines—ICEM 2010, Rome, Italy, 6–8 September 2010; pp. 1–7. [Google Scholar]
- Russell, R.L.; Norsworthy, K.H. Eddy Currents and Wall Losses in Screened-Rotor Induction Motors. Proc. IEE Part A Power Eng. 1958, 105, 163–175. [Google Scholar] [CrossRef] [Scilit]
- Krähenbühl, L.; Muller, D. Thin layers in electrical engineering. Example of shell models in analysing eddy-currents by boundary and finite element methods. IEEE Trans. Magn. 1993, 29, 1450–1455. [Google Scholar] [CrossRef] [Scilit]
- Chemkha, H. Numerical Method for Eddy-Current Computation in a Nonsimply Connected Thin Conducting Shell. IEEE Trans. Magn. 2000, 36, 3920–3925. [Google Scholar] [CrossRef] [Scilit]
- Nguyen, T.T.; Meunier, G.; Guichon, J.M.; Chadebec, O. 3-D Integral Formulation Using Facet Elements for Thin Conductive Shells Coupled With an External Circuit. IEEE Trans. Magn. 2015, 51, 1–4. [Google Scholar] [CrossRef] [Scilit]
- Linz Center of Mechatronics GmbH. The System Model Space. 2021. Available online: https://symspace.lcm.at/ (accessed on 15 April 2021).
- Meeker, D. Finite Element Method Magnetics. 2021. Available online: http://www.femm.info (accessed on 15 April 2021).
- Ansys, Inc. Ansys Electronics Desktop. 2021. Available online: https://www.ansys.com/products/electronics (accessed on 15 April 2021).
- Warberger, B.; Kaelin, R.; Nussbaumer, T.; Kolar, J.W. 50-Nm/2500-W Bearingless Motor for High-Purity Pharmaceutical Mixing. IEEE Trans. Ind. Electron. 2012, 59, 2236–2247. [Google Scholar] [CrossRef] [Scilit]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2021 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).