Article

Design and Redundancy Control Approach of a Novel Three-Platform Parallel-Coupled Mobile Robot

1
School of Mechanical Engineering, North University of China, Taiyuan 030051, China
2
School of Intelligent Engineering, Jinzhong Institute of Information and Technology, Taigu, Jinzhong 030800, China
*
Author to whom correspondence should be addressed.
Machines 2026, 14(9), 1080; https://doi.org/10.3390/machines14091080
Submission received: 31 July 2026 / Revised: 8 September 2026 / Accepted: 16 September 2026 / Published: 19 September 2026
(This article belongs to the Section Robotics, Mechatronics and Intelligent Machines)

Abstract

Based on the advantages of redundancy, high stiffness, and strong load-bearing capacity of parallel mechanisms, they can be applied in the field of mobile robots. This paper proposes a novel three-platform parallel-coupled mobile robot and conducts motion analysis and dynamic modeling for it. It proposes an active internal force regulation strategy and a driving force synchronization and coordination control strategy based on the idea of collaborative integration, and optimizes these two control strategies using neural network methods. Finally, prototype experimental tests show that compared with force–position hybrid control, the active internal force regulation reduces internal force error to 11.6% of the initial value, which is further reduced to 6.5% after neural network optimization; the synchronization–coordination control cuts branch driving error to 10.2% of the initial value and further to 5.1% via neural network optimization. Adaptive compensation for residual coupling and model uncertainty is achieved, further realizing high-precision convergence of internal force errors. This provides a reliable internal force control guarantee for stable collaboration and high-precision operation of robots.

1. Introduction

With the advancement of robotics, interdisciplinary research has been widely conducted to explore effective approaches for improving robot performance to satisfy operational requirements in diverse tasks and environments [1,2,3,4]. In complex and hazardous mobile environments, the robot is required to perform autonomous obstacle avoidance when encountering obstacle-cluttered terrains, so as to reduce the risk of collision [5,6]. Compared with serial mechanisms, parallel mechanisms feature no accumulated positioning errors. However, they are restricted by relatively limited workspace and the occurrence of singular configurations. In terms of actuation modes, parallel mechanisms are categorized into non-redundant actuation and redundant actuation. A parallel mechanism adopts non-redundant actuation when the number of actuators equals the degrees of freedom (DOFs) of its end-effector. By contrast, redundant actuation means that the total number of actuators exceeds the system’s inherent DOFs [7,8,9]. Adding redundant actuated joints can effectively suppress singular configurations of parallel mechanisms and accordingly expand their effective workspace. In addition, optimizing the force distribution among actuators helps enhance the overall actuation performance of parallel mechanisms.
Extensive research on redundant actuation has been conducted by numerous scholars. Feng and Han et al. [10,11] developed a redundantly actuated parallel robot with a 2-RRR parallel mechanism. Servo motors were adopted for positional joints and pneumatic cylinders for redundant joints. A cross-coupling-based force–position cooperative control method was proposed to address the actuation coupling issue. Wen et al. [12,13] presented a 6PUS-2HKP redundantly actuated parallel robot for mastication, which consists of six PUS driving limbs and two point-contact higher pair constraints. This robot has six actuators for four degrees of freedom (DOFs), thus featuring redundant actuation. A torque optimization-based force/position hybrid control (OTDFP) was proposed to resolve the unbalanced driving force. Experimental results demonstrated that this control scheme reduces joint torque fluctuation, accurately reproduces mastication trajectories and bite forces, and improves the dynamic stability of the system. Wen et al. [14,15,16] designed a 5-DOF parallel mechanism with a 6PUS/UPU configuration, which is composed of six PUS driving limbs and one UPU constraint limb with inherent actuation redundancy and inter-limb coupling. Adopting a hierarchical position–force framework, they proposed a hybrid control strategy combining two-degree-of-freedom fractional-order internal model position control and fuzzy fractional-order force control to improve the accuracy of position tracking and force output, respectively. Nevertheless, the above-mentioned studies are limited to passive internal force distribution and local force–position coordination of single-platform redundantly driven mechanisms.
Sakurai and Shikata et al. [17,18,19,20] carried out a series of control studies on redundantly actuated parallel robots. They successively investigated singularity-free parallel robots, planar parallel mechanisms, and cable-driven redundant parallel mechanisms. A mode-space-based force/position hybrid control method was developed, where disturbance observers were employed to suppress external disturbances, achieving high-precision trajectory tracking and direct internal force regulation. Experimental validations proved that the proposed method yields lower trajectory errors and stronger anti-disturbance capability, and effectively enhances the motion accuracy and stability of parallel robots. Xi et al. [21] proposed a single-DOF redundant parallel mechanism and adopted a velocity–force-coordinated control strategy. Closed-loop kinematic and static models were established, and the mapping relationship between force and velocity was derived. A PI controller was utilized to coordinate the load distribution and motion of dual actuators, so as to suppress force conflict and motion mismatch. Zhang et al. [22,23,24,25] proposed a 2RPU-2SPR redundant parallel mechanism. They adopted computed torque control and force/position hybrid control successively. An adaptive reaching law was introduced to mitigate chattering. In the implemented force/position hybrid control, position closed-loop control was applied to non-redundant limbs and force closed-loop control to redundant limbs, which optimizes the distribution of driving forces. Most of these studies are confined to fixed-base parallel mechanisms. Their corresponding control strategies still exhibit deficiencies in scalability and generality, and few works investigate problems such as multi-body coupled dynamics in multi-mobile-platform systems.
Huang et al. [26,27] designed a 6RSS parallel robot for mastication. Considering the requirements of pose–force coordination during mastication, a joint-space impedance control strategy was put forward. Yan et al. [28,29,30] focused on redundant manipulators and proposed several control strategies, including cerebellar-inspired model predictive control, data-driven control, and neurodynamic control. Improved obstacle avoidance constraints were designed, and a neurodynamic solver was used to handle optimization problems. Meanwhile, a discrete Jacobian update law was established to realize model-free adaptive control. Xing and Ding et al. [31,32,33,34,35,36] conducted systematic research on wheeled mobile redundant manipulators. The weighted Jacobian method was used for motion distribution to prioritize the operation of the manipulator. A hierarchical internal model control framework was constructed, and nonlinear disturbance observers were adopted to estimate interaction forces and realize compliant behavior. In addition, cerebellar-inspired and neurodynamic model predictive control were introduced to enhance trajectory tracking and obstacle avoidance performance. Experimental results verified that these control strategies can significantly improve the motion accuracy, force output performance, and teleoperation stability of the system. Ren, Xu, and Zhang [37,38,39] performed a series of control investigations on 2R1T redundant parallel mechanisms. Their control schemes mainly rely on time delay estimation (TDE), sliding mode control, and force/position hybrid control. A TDE-based integral terminal sliding mode control (TDE-ITSMC) was proposed for robust decoupling to compensate for model uncertainties. Most of the above-mentioned investigations focus on control-strategy analysis for fixed scenarios. The majority of these methods mainly address the control of a single redundantly driven unit within a mechanism. Limited research has been conducted on the coordination among multiple redundant drives. Moreover, the coupling effects among numerous joints are frequently neglected, and passive distribution is mostly adopted for closed-loop internal forces without active regulation mechanisms.
A typical characteristic of redundantly actuated mechanisms is that the number of linearly independent actuators exceeds the system degrees of freedom [40,41,42], and strong coupling exists among driving joints. For mobile robots operating in special underground environments, it is necessary to consider not only the coupling among driving forces but also the position requirements imposed by the working environment. To tackle the above issues, this paper proposes a novel force/position hybrid control strategy based on the synergistic integration concept.
The remainder of this paper is organized as follows. Section 2 presents the kinematic analysis of the mobile robot. Section 3 establishes and verifies the dynamic model, which lays a theoretical foundation for the subsequent controller design. Section 4 develops two control strategies for the three-platform parallel mobile robot. In Section 5, neural networks are adopted to optimize the active internal force control strategy and synchronous coordination control strategy. Section 6 conducts comparative physical simulation tests to evaluate the performance of the two original strategies and their neural network-based optimized versions, thereby verifying the effectiveness of the proposed methods. Finally, Section 7 summarizes the main conclusions of this work and outlines the prospects for future research.

2. Kinematic Analysis of the Three-Platform Parallel-Coupled Mobile Robot

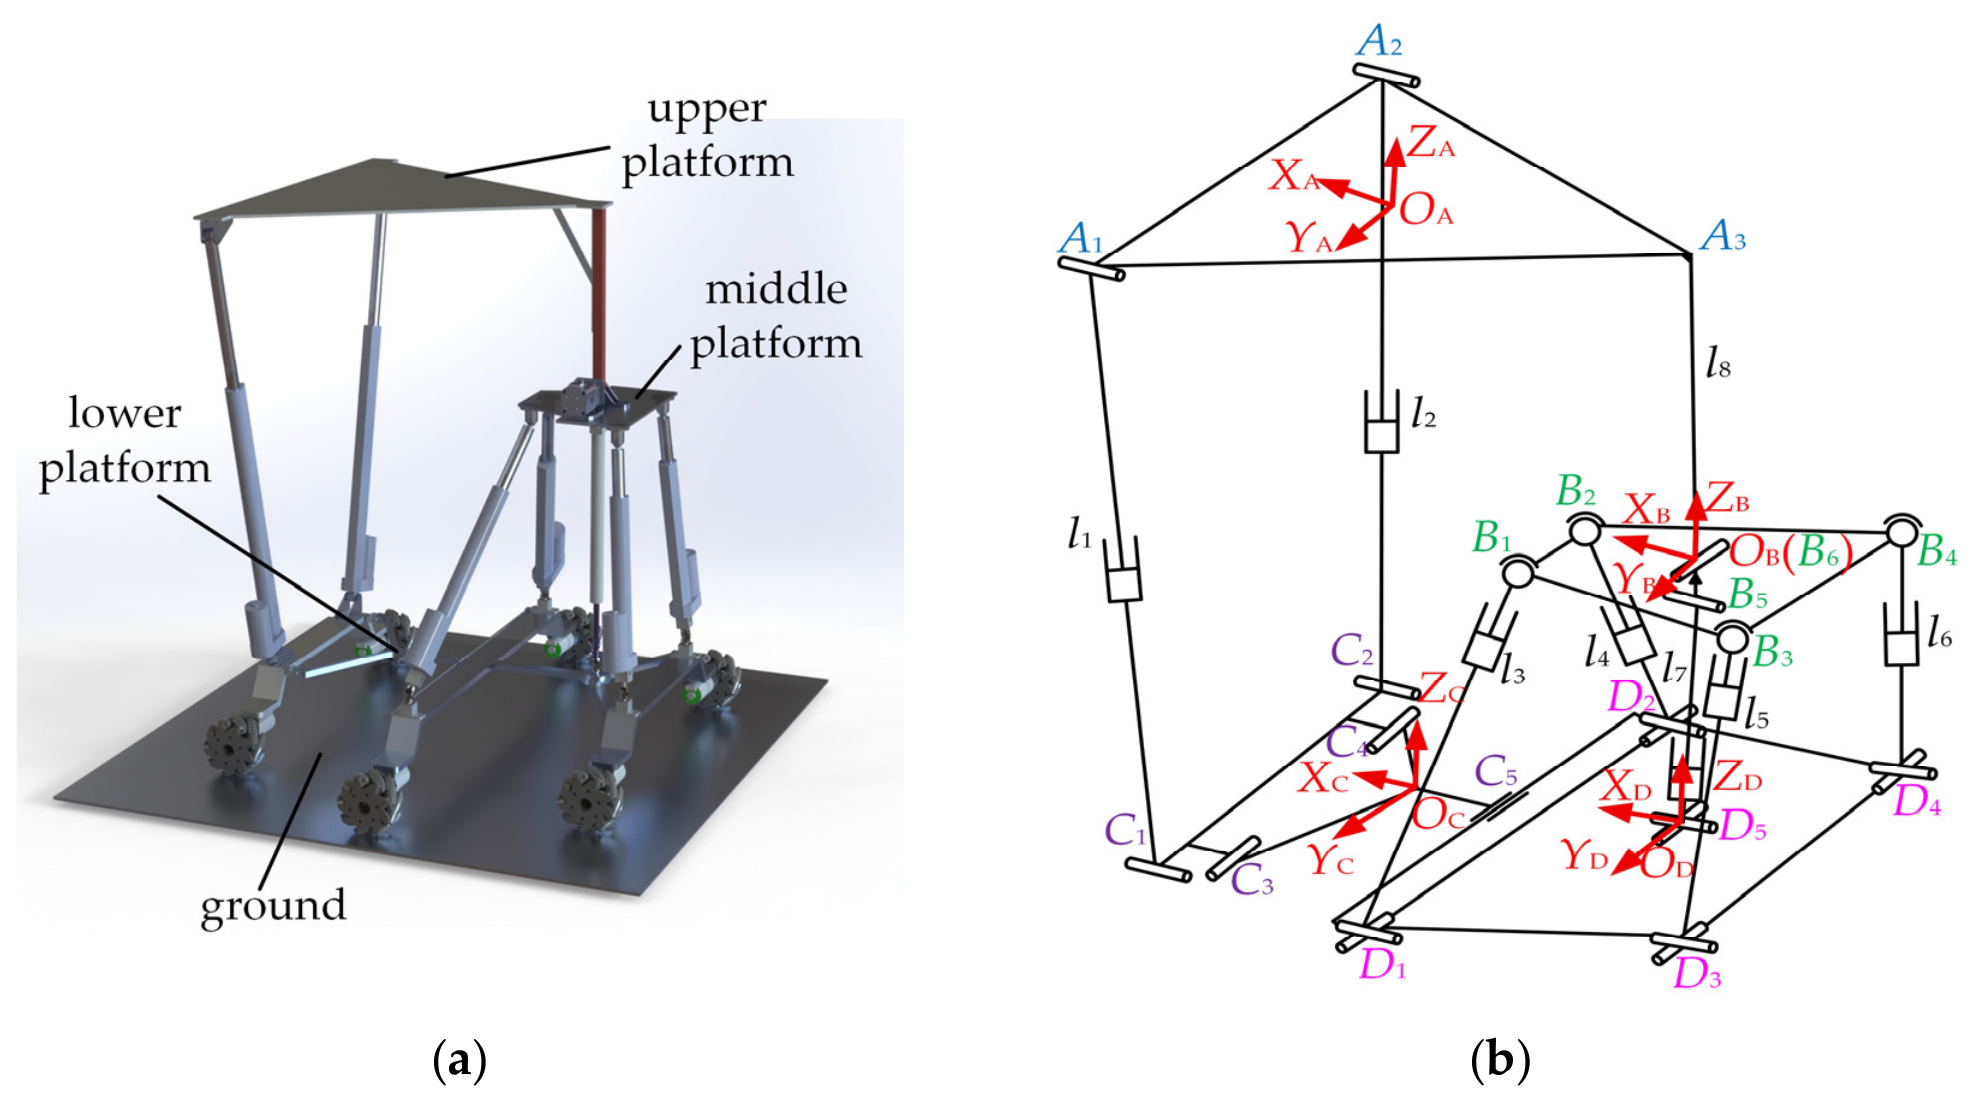
This paper innovatively proposes a three-platform parallel robot. Adopting symmetric structural features, the robot platforms are designed based on the parallelogram rule, and its lower platform is configured as a symmetric foldable-deployable mechanism [43]. The detailed structure is illustrated in Figure 1a. The upper platform is an equilateral triangular loading platform located at the top of the robot. The base corners of the upper triangular platform are connected to the front bracket via two RPR limbs, while its vertex is linked to the middle platform through an R-joint limb.
To avoid collision between the two front RPR limbs and the middle platform during motion, the middle platform is designed as an isosceles trapezoid with a shorter upper base. The revolute joint of the R-joint limb is mounted at the center of the trapezoidal middle platform, and the other end is rigidly connected to the upper platform. The middle platform is connected to the middle bracket and rear bracket by four UPS limbs, and coupled with the second herringbone link via one UPR limb, as illustrated in the figure. To improve the overall stability of the robot, the middle bracket is designed to be longer than the front and rear brackets, where the front and rear brackets have identical dimensions. Mecanum wheels are installed at both ends of the front, middle, and rear brackets.
The first herringbone link is connected to the front bracket by two revolute joints and to the middle bracket by one cylindrical joint. The second herringbone link is fixedly integrated with the middle and rear brackets. For structural analysis simplification, the lower platform is divided into Lower Platform I and Lower Platform II. Lower Platform I consists of the front bracket and the first herringbone link, and Lower Platform II is composed of the middle bracket, the second herringbone link, and the rear bracket. Herein, the parallel mechanism formed by the middle platform, Lower Platform II, four UPS limbs, and one UPR limb is defined as the sub-parallel mechanism.
To facilitate the analysis of locomotion performance of the mobile robot, its schematic diagram is drawn as shown in Figure 1b. The left side of the diagram indicates the forward direction of the robot. Coordinate systems are established on different moving platforms in the schematic. Kinematic pairs are mounted on each platform with their centerlines arranged on the same plane. Accordingly, the gaps between kinematic pairs and platforms are neglected in the spatial coordinate analysis. As illustrated in Figure 1b, the upper platform is an equilateral triangle denoted by A1A2A3. The middle platform consists of four spherical joints forming an isosceles trapezoid B1B2B3B4. The lower platform is designed with deformable and foldable structures, which is composed of a front bracket, a middle bracket, a rear bracket, the first herringbone link, and the second herringbone link. The assembly of the front bracket and the first herringbone link is defined as Platform I, represented by C1C2D1D2. The combination of the middle bracket, the rear bracket, and the second herringbone link is defined as Platform II, denoted by D1D2D3D4. The front bracket and the rear bracket share an identical structure. To guarantee the stability of the mobile robot, the middle bracket is designed with a larger dimension. The geometric relationship satisfies D1D2 > C1C2 = D3D4.
Coordinate systems OA-XAYAZA, OB-XBYBZB, OC-XCYCZC, and OD-XDYDZD are established on the upper platform, middle platform, Lower Platform I, and Lower Platform II, respectively. The origins of the four coordinate systems are located at the geometric centers of the corresponding platforms. The X-axis of each coordinate system points along the forward direction of the wheeled-legged robot, and the Z-axis points vertically upward. The direction of the Y-axis is determined by the right-hand rule. Marked as A1 and A2 in the figure, two revolute joints are mounted on the upper platform, and their rotational axes are aligned with the XA-axis of OA-XAYAZA. The upper platform is rigidly connected to the link of the R-joint at point A3. On the middle platform, points B1–4 denote four spherical joints. B5 and B6 are two revolute joints with mutually perpendicular axes, which are arranged at the center of the lower and upper surfaces of the middle platform, respectively. The rotational axis of joint B5 coincides with the XB-axis of OB-XBYBZB, while the axis of joint B6 is parallel to the YB-axis. The link between the upper platform and the middle platform is denoted as A3B6. For Lower Platform I, there are four kinematic joints labeled C1–4. Among them, C1 and C2 are revolute joints whose rotational axes are parallel to those of A1 and A2. The rotational axes of C3 and C4 are parallel to the YC-axis of OC-XCYCZC. In Figure 1b, C1 and C3, and C2 and C4 are drawn in a staggered layout for visual distinction, whereas they are actually arranged in the front–rear direction. The spacing between them can be neglected in numerical calculations. C5 represents a cylindrical joint that connects Lower Platform I and Lower Platform II, and its axis is parallel to the axes of C3 and C4. Lower Platform II is equipped with five kinematic joints D1–5, all of which are universal joints. One rotational axis of each universal joint is parallel to the YD-axis of OD-XDYDZD. Key structural parameters of the schematic are defined hereinafter. The connections of A1C1, A2C2, B1D1, B2D2, B3D3, B4D4, and B5D5 are realized via prismatic joints, and the lengths of these seven links are defined as l1–7 correspondingly. The rigid link A3B6 has a constant length denoted by l8. Lower Platform I and Lower Platform II are congruent isosceles trapezoids, with the short side, long side and height defined as a1, b1 and k1, respectively. For the middle platform, the short side, long side, and height are denoted as a2, b2, and k2. The upper platform is an equilateral triangle, whose side length and height are represented by a3 and k3.
The inverse kinematics analysis of the mobile robot refers to the inverse kinematic solution of its parallel mechanism. Given the pose parameters (x, y, z, α, β, γ) of the moving platform in space, the inverse kinematics aims to calculate the linear or angular displacements of the actuators. These six parameters represent the translational motions along three coordinate axes and rotational motions about the corresponding axes in the coordinate system established on the fixed platform.
Let the pose of the middle platform coordinate system relative to the coordinate system of Lower Platform II be defined as (x1, y1, z1, α1, β1, γ1). The variable x1 is not an active displacement but a passive motion induced by other movements. Rotation about the XD-axis has no effect on x1, which yields x1 = z1tanβ1. In addition, no rotation occurs about the ZD-axis, so γ1 = 0. Referring to the schematic diagram of the mobile robot in Figure 1b, the prismatic joints of the four UPS limbs are selected as actuators. The lengths of the corresponding four links are denoted by li(i = 3, 4, 5, 6), namely B1D1 = l3, B2D2 = l4, B3D3 = l5 and B4D4 = l6. The middle platform, Lower Platform I and Lower Platform II are all isosceles trapezoids, and Lower Platform I is congruent to Lower Platform II. All geometric dimensions are defined based on the joints connecting the limbs. The upper platform is an equilateral triangle. Accordingly, the equation for calculating the height k3 of this equilateral upper platform can be derived.
k 3 = k 1 + k 1 2 a 1 + b 1 3 a 1 + b 1
Accordingly, the side length of the equilateral triangular moving platform, denoted by a3, can be derived as follows. To simplify the calculation, let λi represent the ratio of the distance from the geometric center of the isosceles trapezoid to its long side to the total height of the trapezoid. The corresponding equations are obtained as below.
λ i = 2 a i + b i 3 a i + b i       ( i = 1 , 2 )
As shown in Figure 1b, four coordinate systems are established for the mobile robot. The coordinates of two endpoints of each link in the coordinate system of Lower Platform II can be determined. The coordinates of each point on the middle platform in the coordinate system OD-XDYDZD can be expressed as:
B i O D = T 1 B i O B + P 1       ( i = 1 , 2 , 3 , 4 )
where P1 denotes the spatial position vector of the origin of the middle platform coordinate system with respect to the coordinate system OD-XDYDZD, i.e., P1 = [x1 y1 z1]T. T1 is the coordinate transformation matrix obtained under the X-Y-Z Euler-angle mode for degrees of freedom. Accordingly, the coordinates of points in the coordinate system OB-XBYBZB can be derived in OD-XDYDZD. Similarly, the coordinates of points belonging to the coordinate system OA-XAYAZA can also be expressed in OD-XDYDZD. On this basis, the lengths of all links are calculated via the closed-loop vector method, and the inverse kinematic solutions are further obtained.
l 3 = B 1 O D D 1 O D 2 , l 4 = B 2 O D D 2 O D 2 , l 5 = B 3 O D D 3 O D 2 , l 6 = B 4 O D D 4 O D 2
For the upper platform analysis, its pose relative to the coordinate system of Lower Platform II is defined as (x2, y2, z2, α2, β2, γ2). Since no rotation about the ZD-axis exists for the upper platform, we have γ2 = 0. The pose of the upper platform is mainly determined by the rotation angle of the revolute joint on the R-joint link. The rotational angle of the upper platform coordinate system about the YB-axis with respect to the middle platform coordinate system is defined as θ1, which equals the rotation angle of the aforementioned revolute joint.
Since x1 = z1tanβ1, the value of β1 can be solved. The rotation angles of the upper platform and the middle platform about the XD-axis are identical, namely α1 = α2.
β 1 = arctan x 1 z 1
The rotation angle β2 of the upper platform coordinate system about the YD-axis equals the sum of β1 (the rotation angle of the middle platform coordinate system about the YD-axis) and θ1 (the rotation angle of the revolute joint on the R-joint link).
θ 1 = β 2 β 1
With the aid of the closed-loop vector method, the linear displacements of the prismatic joints in the two RPR limbs connecting the upper platform and Lower Platform I can be calculated.
l 1 = A 1 O D C 1 O D 2         l 2 = A 2 O D C 2 O D 2
In summary, Equations (4), (6) and (7) constitute the inverse kinematic solutions of the three-platform parallel mobile robot.

3. Dynamic Modeling of the Three-Platform Parallel-Coupled Robot

With the advancement of robotics, interdisciplinary research has been conducted to explore effective approaches for improving robot performance to meet operational requirements in diverse tasks and environments. As a national strategic development direction in China, “Coexisting-Cooperative-Cognitive” (Tri-Co) Collaboration has attracted widespread attention. A Tri-Co robot can adapt to environments and perform collaborative operations through real-time interaction with working conditions and environments, as well as information exchange between operators and robots [44,45]. Its core characteristics lie in superior adaptability to complex and unstructured dynamic environments, good perception of human operating behaviors, and the capability to realize human–robot and robot–robot collaboration within specified rules. Reconfigurable robots can adjust their configurations and postures according to various tasks, thus enhancing their trafficability in complex scenarios. The three-platform parallel robot studied in this work is designed for complex underground environments, and it needs to fulfill multiple functions, including mutual constraint, cooperative operation, and autonomous perception among the three platforms and connecting links. In terms of structure, the upper platform and its connecting links with the sub-parallel mechanism form an independent unit, while the sub-parallel mechanism composed of the middle and lower platforms serves as another separate unit, which constitutes an internal collaboration mechanism. Since the robot operates in intricate underground environments and requires continuous information interaction with the surroundings, it is of great significance to investigate Tri-Co Collaboration for the proposed three-platform parallel-coupled mobile robot.
Prior to dynamic analysis of redundantly actuated parallel mechanisms, an appropriate dynamic model needs to be established. Such mechanisms are featured with more actuators than system degrees of freedom. At present, multiple methods are available for dynamic modeling of parallel mechanisms. These methods differ in solution procedures and model forms, yet they yield identical results for driving forces. In this paper, the principle of virtual work is adopted for dynamic modeling, due to its clear derivation process and definite physical meaning. To simplify the calculation, the frictional effects between components are neglected during model establishment.

3.1. Dynamic Modeling of Non-Redundantly Actuated Robots

The frictional forces at joints between all components are neglected. The motion of the non-redundantly actuated mobile robot is mainly affected by inertial forces, gravity, external loads, and driving forces generated by actuators. Under the non-redundant control mode, the driving vector of the robot is expressed as
d n r = l 3 , l 4 , l 5 , l 6 , θ 1 T
The independent pose parameters of the upper platform relative to Lower Platform II (the fixed platform) are given as follows.
q = x 2 , y 2 , z 2 , α 2 , β 2 T R 5
In the above formula, x2, y2 and z2 denote the position coordinates of the origin OA of the upper platform coordinate system in OD-XDYDZD established on the fixed platform (Lower Platform II). α2 and β2 represent the rotation angles of the upper platform about the XD-axis and YD-axis of the fixed platform coordinate system, respectively. Since no rotation about the ZD-axis occurs between the upper platform and the fixed platform, γ2 = 0. Under this condition, the pose of the middle platform relative to the fixed platform can be solved via inverse kinematics, and the velocity equations of the middle platform are further derived accordingly.
q ˙ m = J m q ˙
The Jacobian matrix J m R 5 × 5 in the equation is obtained by differentiating the inverse kinematic solutions with respect to time.
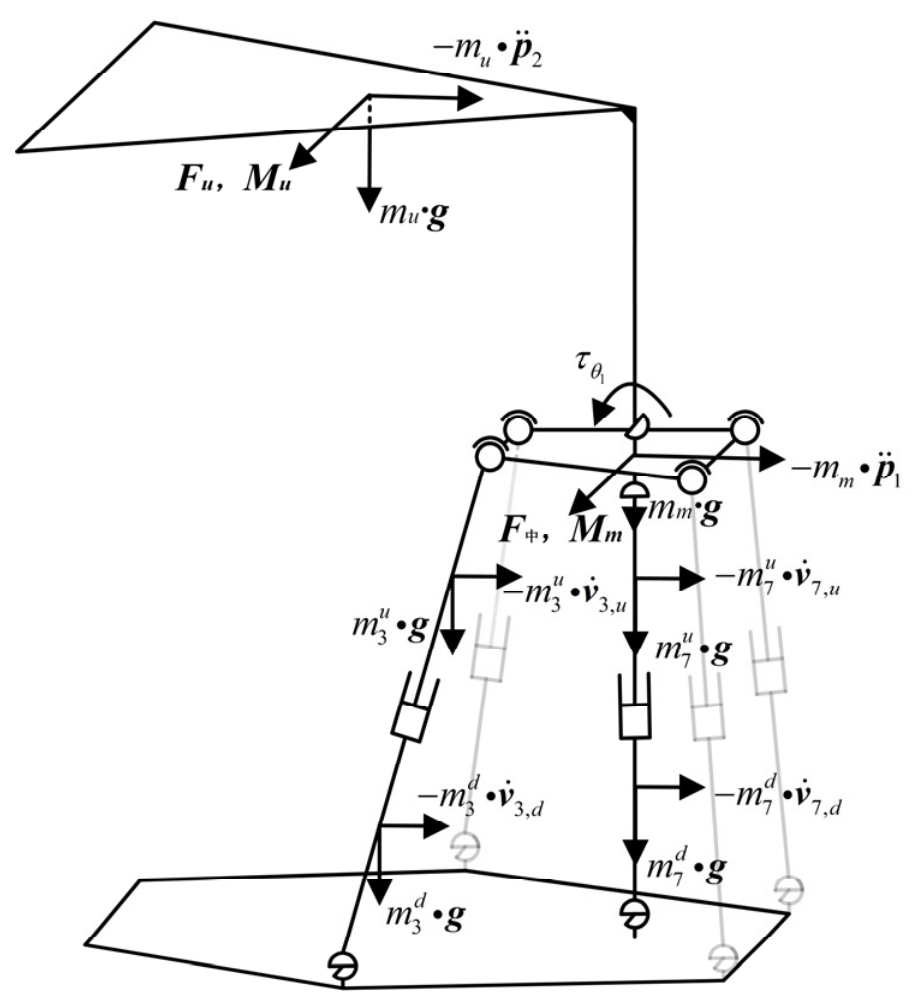
The virtual work of the mobile robot is solved by dividing its structure into separate parts. We first analyze the virtual work of the upper platform. Since the upper platform is rigidly connected to the R-joint link, the two components are collectively referred to as the upper platform. Let the mass of the upper platform be mu. The centroid of the upper platform deviates slightly from the origin OA of its coordinate system due to the additional rigid link. Its inertia tensor expressed in the upper platform coordinate system is a constant matrix denoted as I u l o c a l = d i a g I u x , I u y , I u z . Based on the rotation matrix of the upper platform relative to the fixed platform derived previously, the inertia tensor of the upper platform with respect to the fixed platform is I u = R A I u l o c a l R A T , where RA stands for the rotation matrix of the moving platform relative to the fixed platform and can be obtained from inverse kinematics. The translational velocity of the upper platform in the fixed coordinate system is expressed as
p ˙ 2 = x ˙ 2 , y ˙ 2 , z ˙ 2 T = T v   q ˙
In the formula, the angular velocity ω2 corresponding to T v = I 3 × 3 , 0 3 × 2 can be derived from the derivatives of Euler angles.
ω 2 = α ˙ 2 cos β 2 β ˙ 2 α ˙ 2 sin β 2 = T ω   q ˙
The term Tω in the above formula denotes
T ω = 0 0 0 cos β 2 0 0 0 0 0 1 0 0 0 sin β 2 0
In this state, the moving platform is subjected to active forces including gravity and inertial forces. The gravity is denoted as Gu = mug, and the inertial force is expressed as m u p ¨ 2 , with the corresponding inertial moment being I u ω ˙ 2 ω 2 × I u ω 2 . Additionally, the external force and external moment are represented by F e x t R 3 and M e x t R 3 , respectively. The forces and moments acting on the upper platform are assembled into a six-dimensional generalized force vector as
F u = F e x t m u   p ¨ 2 + m u g M e x t I u ω ˙ 2 ω 2 × I u ω 2 R 6
The virtual displacement of the upper platform is expressed as δ X u = δ p 2 ; δ θ 2 , where δ θ 2 = T ω δ q is defined as follows. Accordingly, the virtual work of the moving platform is derived as
δ W u = δ X u T F u = δ q T T v T F e x t m u p ¨ 2 + m u g + T ω T M e x t I u ω ˙ 2 ω 2 × I u ω 2
Next, the virtual work of the middle platform is solved. Let the mass of the middle platform be mm, and its inertia tensor be Im, which is a constant in the local coordinate system. Its pose is described by q m = y 1 , z 1 , α 1 , β 1 T as defined previously. The follow-up translation along the X-axis of the middle platform can be calculated by the formula x1 = z1tanβ1. Based on inverse kinematics, the velocity mapping relation of the middle platform is expressed by q ˙ m = J m q ˙ , associated with the Jacobian matrix J m = q m / q . The translational velocity of the middle platform is written as
p ˙ 1 = x ˙ 1 , y ˙ 1 , z ˙ 1 T = T v 1 q ˙ m
In the formula, the angular velocity ω1 corresponding to T v 1 = I 3 × 3 , 0 3 × 2 can be obtained from the derivatives of Euler angles.
ω 1 = α ˙ 1 cos β 1 β ˙ 1 α ˙ 1 sin β 1 = T ω 1 q ˙ m
The definition of Tω1 is similar to that of Tω, with only the angles replaced by α1 and β1. As the middle platform is an internal component of the robot, it is free from external forces. Its generalized force is expressed as
Q m = J m T T v 1 T m m p ¨ 1 + m m g + T ω 1 T I m ω ˙ 1 ω 1 × I m ω 1
The virtual work of the middle platform is obtained as δ W m = δ q T Q m .
We then analyze the virtual work of the driving branches in the sub-parallel mechanism. Each of the four UPS driving branches consists of two links, namely the upper link and the lower link. The lower link is adjacent to the fixed platform, while the upper link is adjacent to the moving platform. Let the mass of the upper link of each UPS branch be m i u and the mass of the lower link be m i d (i = 3, 4, 5, 6). The subscript i of all driving branches ranges from 3 to 6. Taking the centroid of each link as the reference, the inertia tensor of each link is constant in its local coordinate system. When transformed into the coordinate system of the fixed platform, the inertia tensors of the upper and lower links are denoted as I i u and I i d respectively. The axes of the two links are collinear.
The sliding velocities of the upper and lower links can be obtained via inverse kinematics as
l ˙ i = n i T v B i v D i = n i T v B i
Calculate the virtual work of each branch and synthesize the overall inertia tensor. First is the virtual work of the lower link. The lower link is subjected to gravity m i d g , inertial force m i d   v ˙ i , d and the corresponding inertial moments I i , d ω ˙ i , d ω i , d × I i , d ω i , d . Its virtual work is expressed as
δ W i , d = δ q T J i , d T m i d v ˙ i , d + m i d g I i , d ω ˙ i , d ω i , d × I i , d ω i , d
Similarly, the virtual work of the upper link can be derived. By combining the virtual work and inertia tensors of the upper and lower links, the total virtual work of a single driving branch is obtained as
δ W i = δ W i , u + δ W i , d
The driving forces of the actuators act along the axial direction of the moving links. Depending on extension and retraction, the forces apply to the upper or lower end of the branch links and are essentially axial forces. Accordingly, the virtual work of each driving force can be calculated. Finally, the total virtual work of each UPS branch is derived as
δ W l i = δ W i , u + δ W i , d + δ W d r i v e , i = δ q T Q i i n e r t i a
The sub-parallel mechanism contains five connecting branches, among which four are driving branches, and one is a passive UPR branch. Only gravity and inertial forces are taken into account for the passive branch. It is also composed of an upper link and a lower link, and shares a similar structure with the UPS driving branches. The revolute joint at its upper end has no influence on the dynamic equations established by the virtual work principle. Its velocity and acceleration are expressed in the same form as those of the UPS branches, and the general Jacobian matrix can be adopted.
v 7 , u ω 7 , u = J 7 , u q ˙ ,         v 7 , d ω 7 , d = J 7 , d q ˙
Similarly, the total virtual work of the UPS driving branches and the UPR passive branch can be obtained as
δ W 7 = δ W 7 , u + δ W 7 , d = = δ q T Q 7 i n e r t i a
Finally, there is an actuated revolute joint θ1 connecting the upper platform and the middle platform. The driving moment shown in Figure 2 is denoted as τ θ 1 . According to Equation (5), θ1 = β2β1 and β1 = arctan(x1/z1), so θ ˙ 1 = J θ 1 q ˙ can be solved. The Jacobian matrix J θ 1 R 1 × 5 is derived by differentiating the inverse kinematic equations. Thus, its virtual work is written as
δ W θ = τ θ 1 δ θ 1 = τ θ 1 J θ 1 δ q = δ q T J θ 1 T τ θ 1
In summary, the virtual work of all components in the non-redundant system is summed up. According to the virtual work principle, the total virtual work equals zero. After rearrangement, we obtain
M n r q q ¨ + C n r q , q ˙ q ˙ + G n r q = J n r T q f n r
where M n r q R 5 × 5 is the generalized mass matrix, which is derived from the total kinetic energy of the upper platform, middle platform and all connecting branches; C n r q , q ˙ R 5 × 5 denotes the coefficient matrix of Coriolis and centrifugal forces; G n r q R 5 × 1 is the generalized gravity term; J n r q R 5 × 5 represents the Jacobian matrix under the non-redundant condition, whose row vectors are J θ 1 and J B i T n i i = 3 , 4 , 5 , 6 ; and f n r = f l 3 , f l 4 , f l 5 , f l 6 , τ θ 1 T R 5 is the vector of driving forces and moments. When the mobile robot is at a non-singular configuration, J n r is invertible, and the unique solution of the driving forces is obtained as:
f n r = J n r T q M n r q q ¨ + C n r q , q ˙ q ˙ + G n r q

3.2. Dynamic Modeling of Redundantly Actuated Robots

Under the redundantly actuated condition, the mobile robot is equipped with two additional active RPR branches on the basis of the original five non-redundant actuators. Combining all active actuators, the driving vector of the robot in the redundant actuation mode can be written as:
d r = l 1 , l 2 , l 3 , l 4 , l 5 , l 6 , θ 1 T R 7
The upper platform still has five degrees of freedom in this mode, so the degree of redundancy of the robot is two.
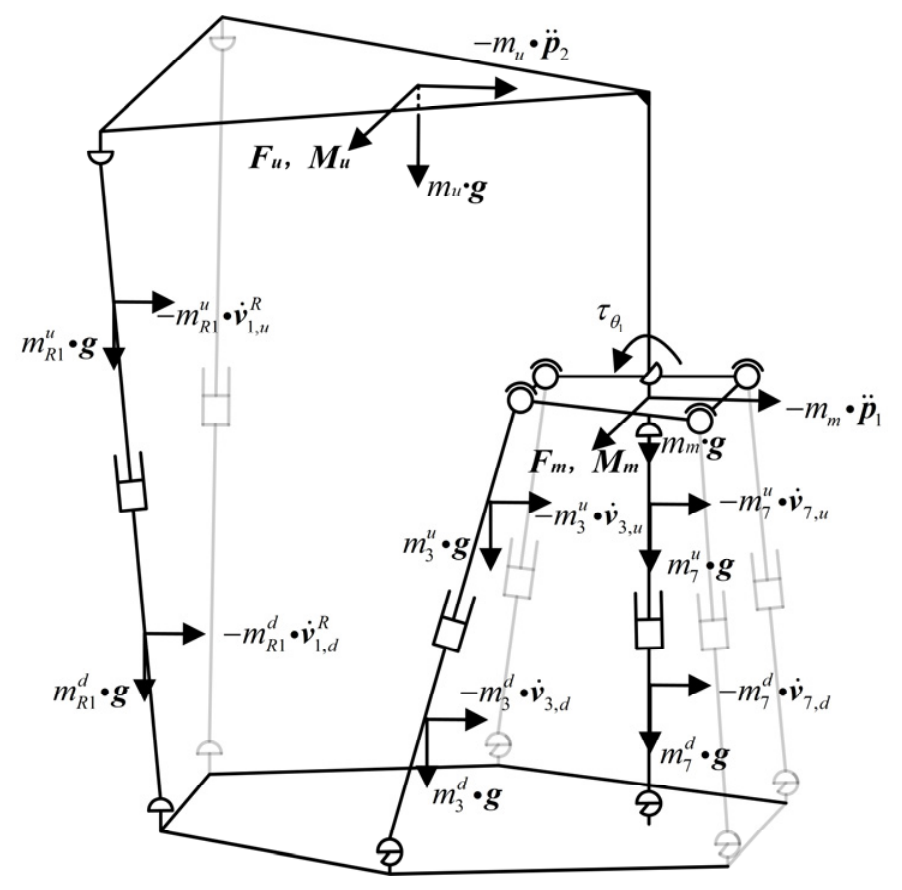
As shown in Figure 3, according to the structural characteristics of the mobile robot, the two RPR branches are connected to the upper platform and the Lower Platform I respectively. The driving lengths of the two branches are defined as lj(j = 1, 2). Each RPR branch is divided into an upper link and a lower link. Let the mass of the upper link be m R j u and the mass of the lower link be m R j d , with the corresponding inertia tensors denoted as I R j u and I R j d .The two endpoints of each branch are defined as Aj and Cj(j = 1, 2). The upper endpoints Aj are connected to the upper platform via revolute joints, while the lower endpoints Cj are mounted on the front bracket of the fixed Lower Platform I. Since the lower platform is stationary, the coordinates of Cj remain constant and their velocities are zero. The velocity of Aj attached to the upper platform is v A j = J A j q ˙ , and J A j is the corresponding Jacobian matrix. Similar to the UPS branches in the non-redundant actuation system, the upper link and lower link share the same angular velocity, which is expressed as
ω j , u R = ω j , d R = n R j × v A j l j
The centroid velocities of the upper and lower links are denoted as v j , u R and v j , d R , respectively. Both can be expressed as a linear combination of the driving velocity l ˙ j and the velocity v A j of the upper endpoint, and can also be written as linear functions of q ˙ .
v j , u R ω j , u R = J j , u R q ˙ ,         v j , d R ω j , d R = J j , d R q ˙
Similarly, the total virtual work of each redundantly actuated RPR branch can be derived as
δ W l j R = δ q T Q j , u R + Q j , d R + J B j T n j f l j
For the virtual work of other components excluding the two RPR branches, the expressions for four UPS driving branches, the upper platform, the middle platform, the UPR branch and the revolute joint θ1 remain consistent with those under the non-redundant constraint mode. Only the driving force terms f l i i = 3 , 4 , 5 , 6 and τ θ 1 among the five driving terms are retained. In summary, the virtual work of all components of the mobile robot is summed up. Based on the virtual work principle, the equation can be rearranged as follows:
M r q q ¨ + C r q , q ˙ q ˙ + G r q = J r T q f r
As the number of variables changes, the corresponding Jacobian matrix varies. Accordingly, J r 7 × 5 and the driving force vector f r 7 can be extended to
J r = J A 1 T n R 1 J A 2 T n R 2 J A 3 T n R 3 J A 4 T n R 4 J A 5 T n R 5 J A 6 T n R 6 J θ 1 T f r = f l 1 f l 2 f l 3 f l 4 f l 5 f l 6 τ θ 1 T
The above formula consists of five equations with seven unknowns, forming an underdetermined system of equations. After prescribing the desired trajectory q t , q ˙ t , q ¨ t of the upper platform, the right-hand term is denoted as τ r e q = M r q ¨ + C r q ˙ + G r , which is a definite and unique five-dimensional vector. Nevertheless, the force vector f r satisfying J r T f r = τ r e q , f r has infinitely many solutions. Consequently, the distribution of driving forces for the redundantly actuated system yields multiple solutions and a unique solution cannot be obtained. Additional constraints are therefore required, which can be formulated according to specific optimization objectives.
Various methods are currently available for solving the driving force distribution of redundantly actuated parallel mechanisms, typically including the least squares method, energy optimization method, generalized inverse method, boundary constraint method, weighted generalized inverse method, and rigid–flexible hybrid method. Since all driving branches of the mobile robot share an identical structure, the generalized inverse method is adopted to simplify the calculation. According to the generalized inverse matrix theory, the minimum-norm solution of the underdetermined constraint equations corresponds to the minimum energy solution of the parallel mechanism, which can be solved by means of the pseudoinverse. The generalized inverse solution is expressed as:
J r T + = J r J r T J r 1 R 7 × 5
Thus, the minimum-norm solution of driving forces for the redundantly actuated system is expressed as:
f r = J r T + τ r e q = J r J r T J r 1 M r q q ¨ + C r q , q ˙ q ˙ + G r q
It should be noted that the pure Moore–Penrose pseudoinverse matrix yields a mathematically minimum-norm solution, which may generate non-physical forces exceeding the output upper limits of the end-effector. Therefore, in the practical design of the control strategy, the force of each actuator should be constrained within a certain range: fi,minfifi,max. During simulation and prototype experiments, force-protection limits shall be enforced in the control loop whenever the computed force exceeds the upper bound of the end-effector.

3.3. Dynamic Simulation Verification of Redundantly Actuated Mobile Robot

Based on the dynamic analysis of the mobile robot under redundant and non-redundant actuation modes, the correctness of the derived dynamic model is verified via Adams. Firstly, the robot model is established in SolidWorks 2022 and then imported into Adams 2022. After assigning actual material properties and driving forces, dynamic simulation is carried out following the preset trajectory of the upper platform. Based on application scenarios, kinematic-performance analysis and dimensional optimization of the robot, the initial structural parameters of the mechanism are obtained as follows: a1 = 306 mm, b1 = 598 mm, k1 = 359 mm, a2 = 102 mm, b2 = 255 mm, k2 = 214 mm, l8 = 275 mm. Since mobile robots frequently encounter obstacles, they are required to perform human-like left–right swinging motions for obstacle avoidance. Accordingly, the upper platform of the mobile robot is designed as a moving component, whose trajectory is defined as periodic swinging along the Y-axis while maintaining a horizontal attitude throughout the whole motion. One complete swinging cycle lasts 16 s, and the lower platform remains stationary during operation. To keep the upper-layer platform horizontal at all times, the middle platform is also constrained to a horizontal state. According to the kinematic singularity analysis, the robot has no singular configurations within this swinging cycle.
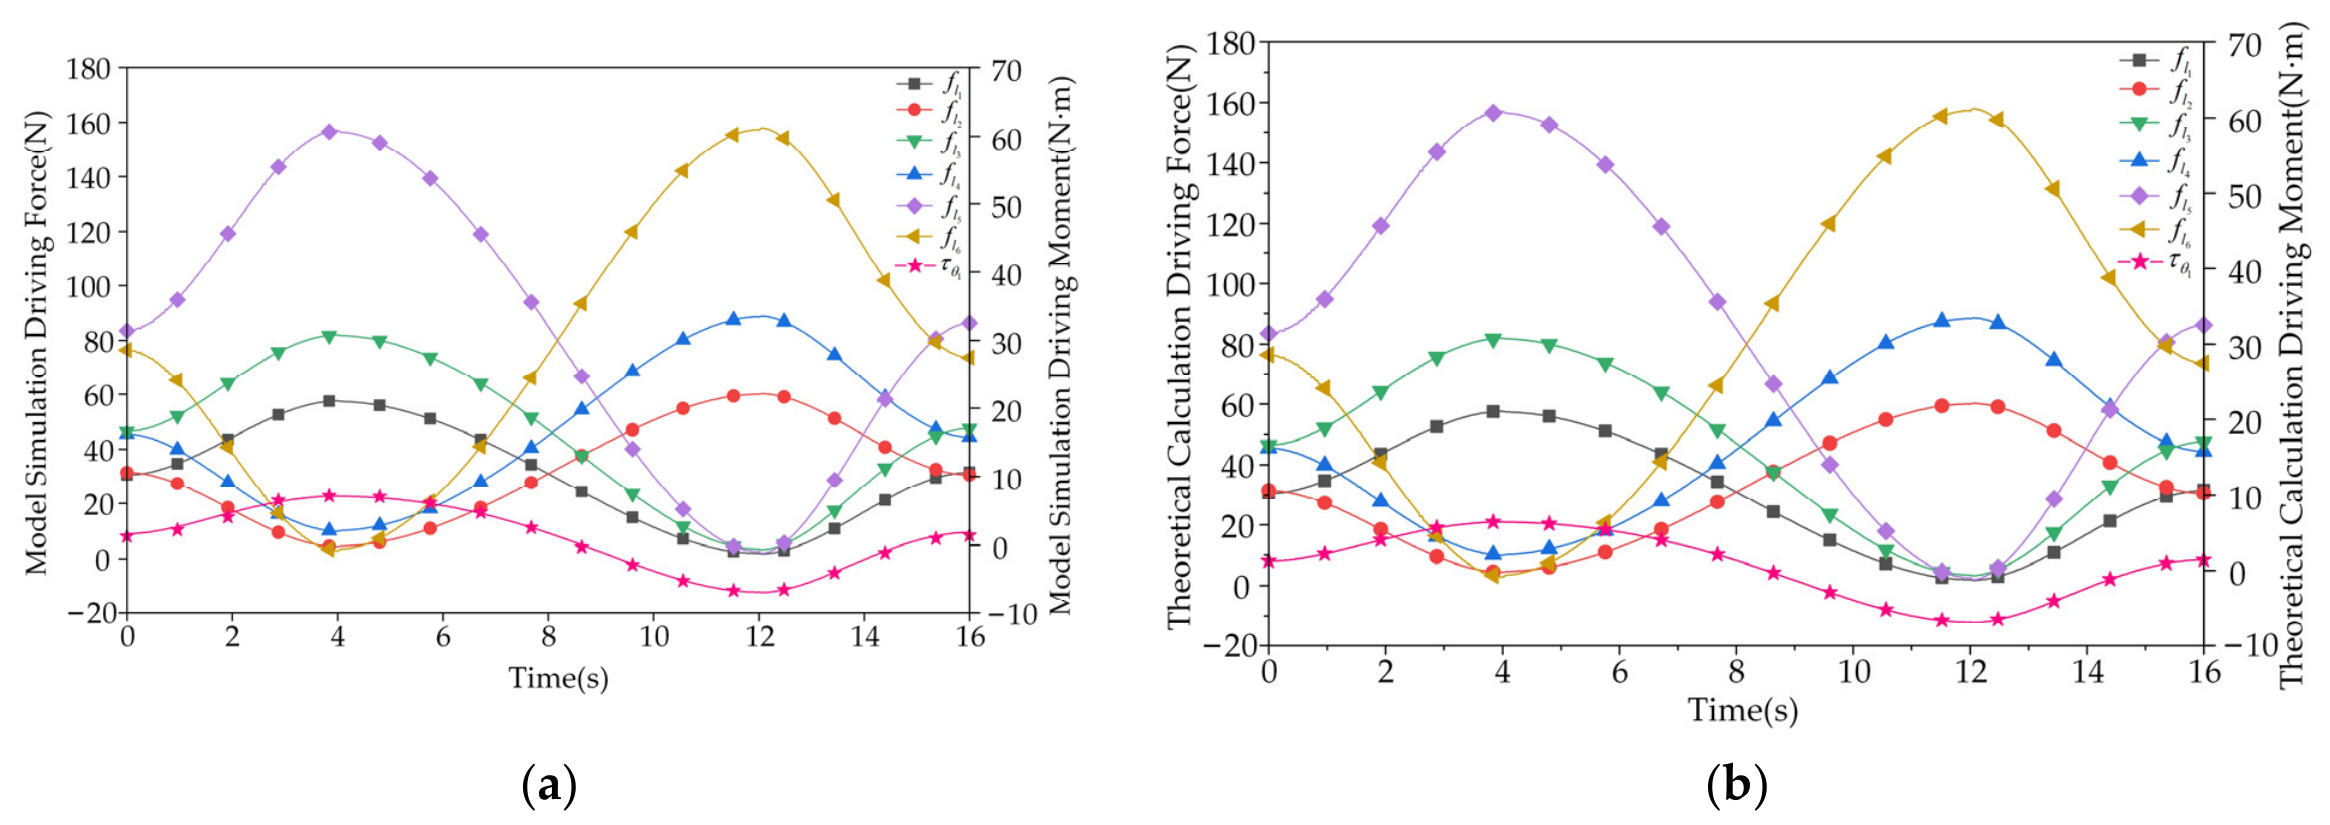
According to the preset swing trajectory of the upper platform, the variation curves of driving forces and moments for #1 to #5 actuators are obtained via inverse kinematics analysis and then imported into Adams. Based on the above dynamic analysis of the mechanism, the force curves of #6 to #7 actuators are calculated and imported to define the loads acting on the two RPR branches. During the simulation in Adams, the linear driving forces and rotational driving moments of #1 to #5 actuators throughout the motion are recorded. The simulation results are further compared with the values calculated by the dynamic model established in this chapter.
It can be seen from Figure 4 that the distribution of driving forces and moments obtained by model simulation is basically consistent with the theoretical calculation results. This verifies that the established dynamic model can accurately reflect the force transmission and load distribution characteristics of the mechanism, and demonstrates the correctness of the model and the reliability of subsequent simulation analysis.


4. Design of Hybrid Force–Position Control Strategy for Collaborative and Inclusive Operation

Traditional hybrid force–position control strategies mainly focus on the motion accuracy and basic internal force regulation of the mechanism. Such task-oriented control methods fail to fully integrate the concept of Tri-Co [44,45]. Therefore, by combining the characteristics of the mobile robot with the inclusive collaboration theory, two adaptive control strategies are proposed in this paper, namely the active internal force regulation strategy and the driving force synchronous coordination control strategy. In this paper, the internal force refers specifically to the physical axial force of the redundant RPR struts measured by sensors, rather than the null-space force in redundant actuation theory. The active internal force regulation strategy aims to realize compliant inclusive collaboration between the mobile robot and the working environment. Through the active closed-loop control of the internal forces of key components, the robot can achieve favorable biomimetic compliance when contacting or bearing external loads from the working environment. This effectively reduces rigid collisions between the robot and the operating environment and improves operational safety. In contrast, the driving force synchronous coordination control strategy focuses on the internal collaborative performance of the robot. By coordinating the output of all internal driving joints and reasonably distributing driving forces, the energy loss caused by internal actuation redundancy is reduced, which further improves the working efficiency of the robot.

4.1. Active Internal Force Regulation Strategy

The core idea of the active internal force regulation strategy is to realize environmentally inclusive collaboration of the robot. When the mobile robot operates in unknown and complex environments, its working components inevitably produce physical collisions with the external environment. Traditional rigid control strategies take zero tracking error as the primary design objective. However, such control methods will generate excessive contact force between the robot and the environment, which may lead to mechanism damage or environmental collapse. To achieve bionic compliant contact performance, the robot is required to possess both force perception and force regulation capabilities, namely controllable environmental compliance. In the proposed control strategy, the redundant actuation system of the robot is taken as the active force regulation module. By adopting closed-loop control to adjust the internal forces of key components, the robot can interact with the working environment according to the preset force–position relationship. This realizes the transition of the robot control mode from rigid control to compliant inclusive collaboration.
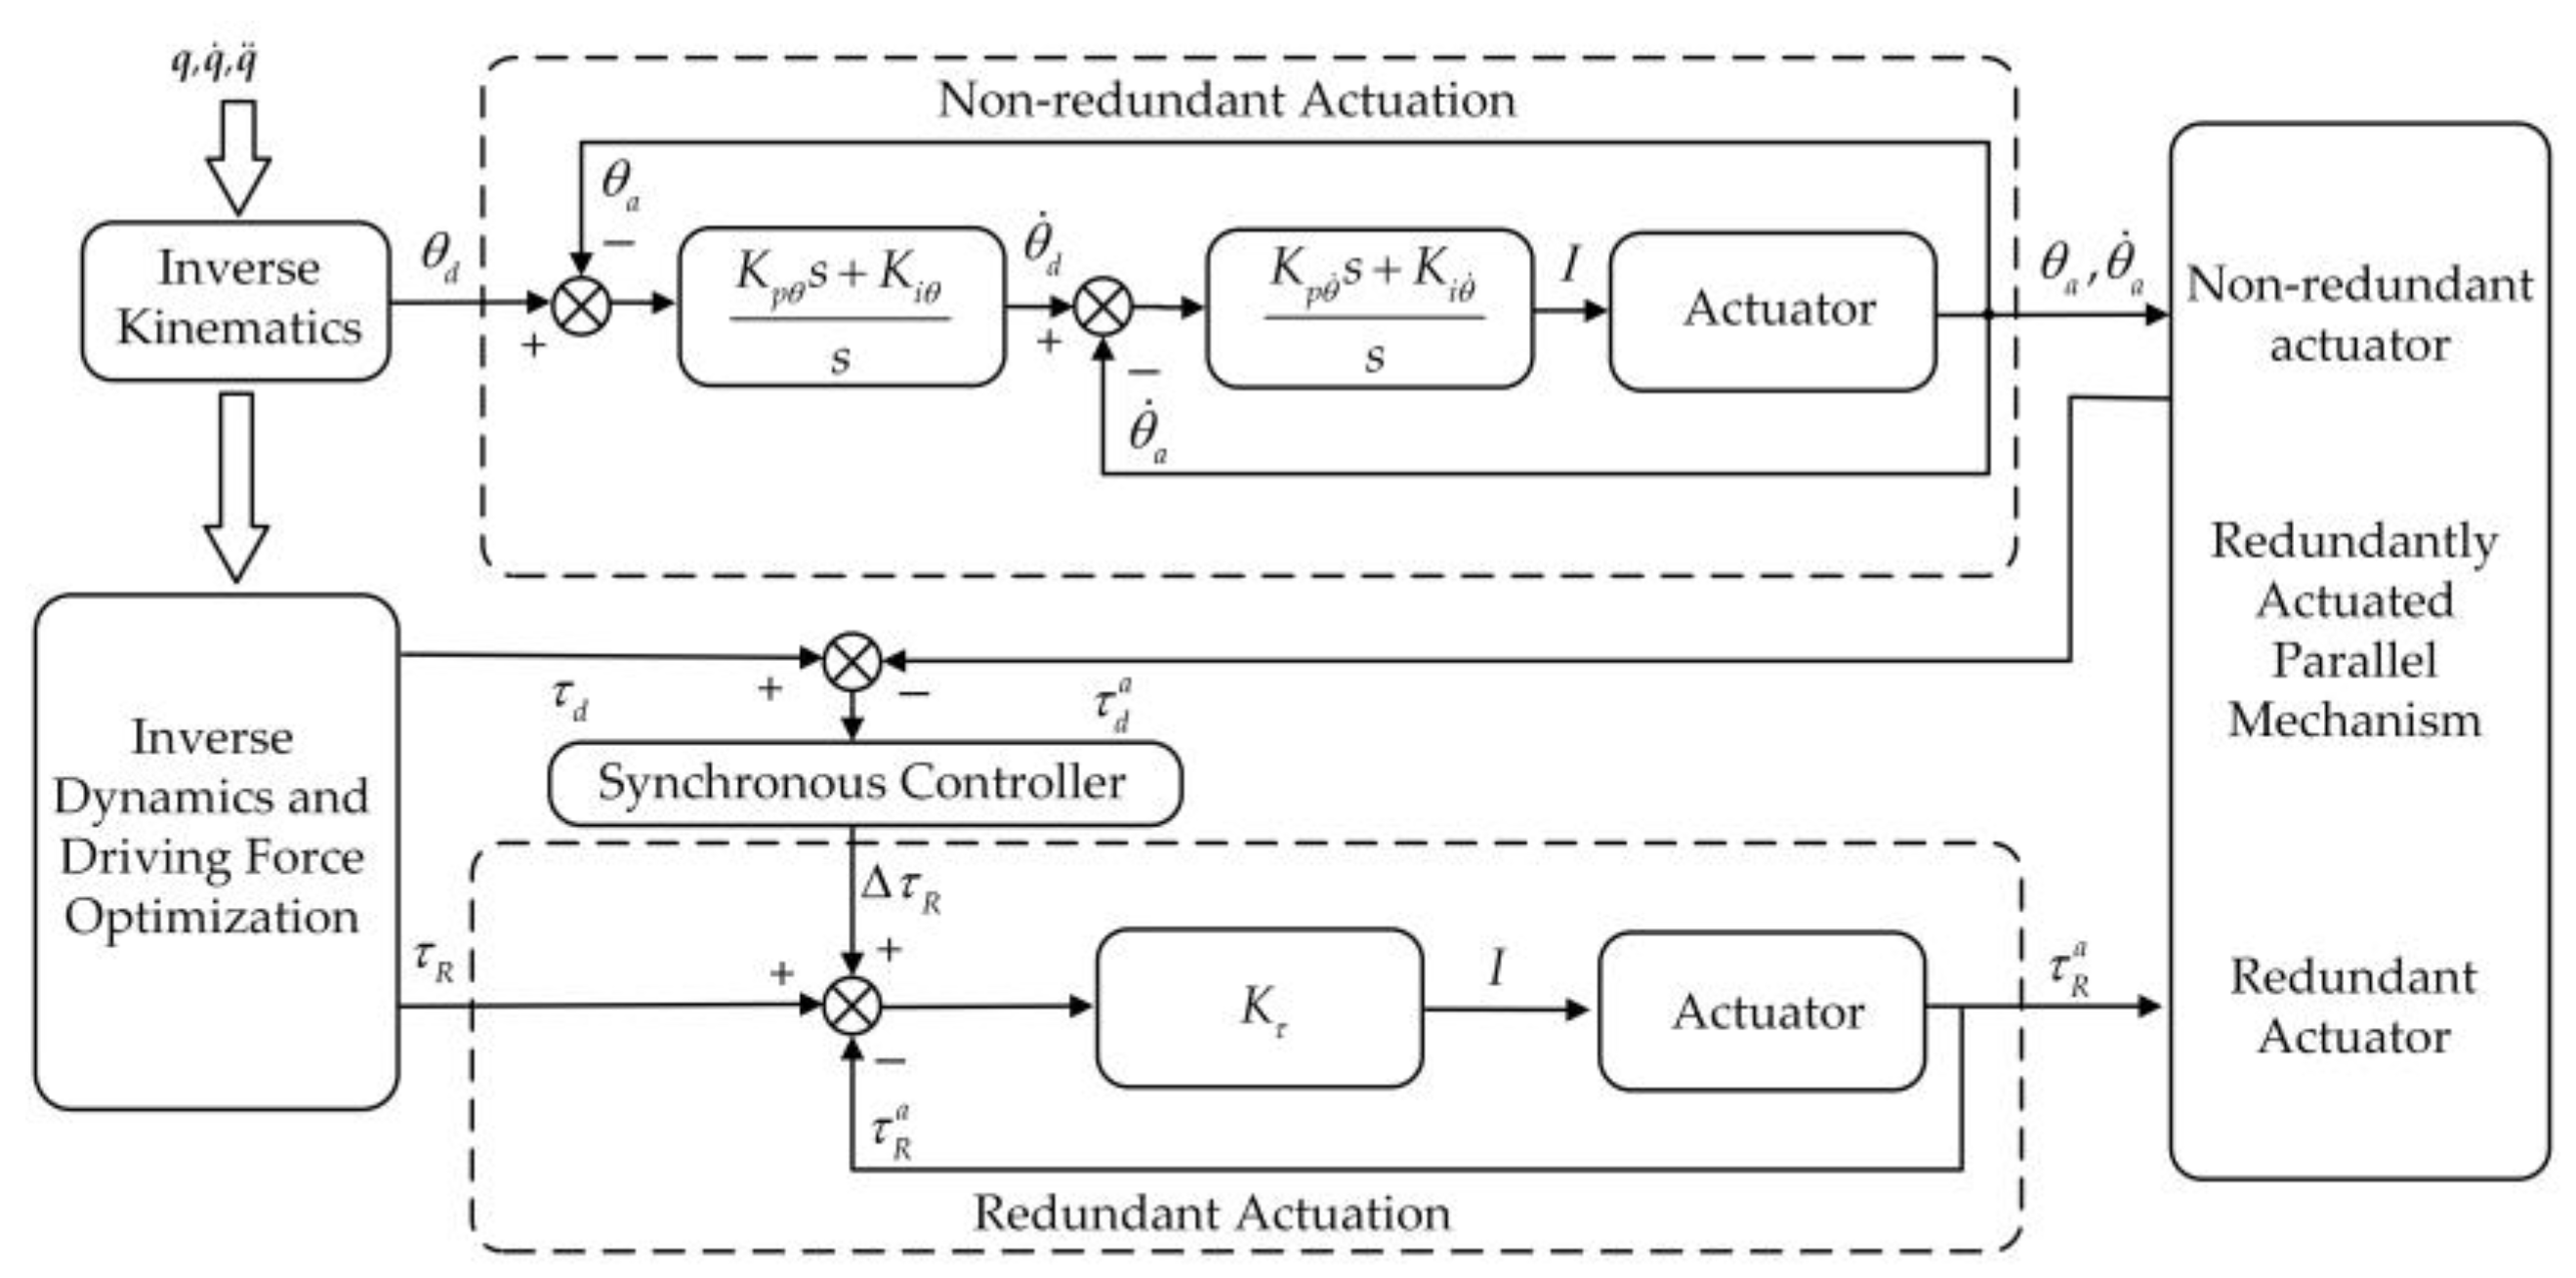
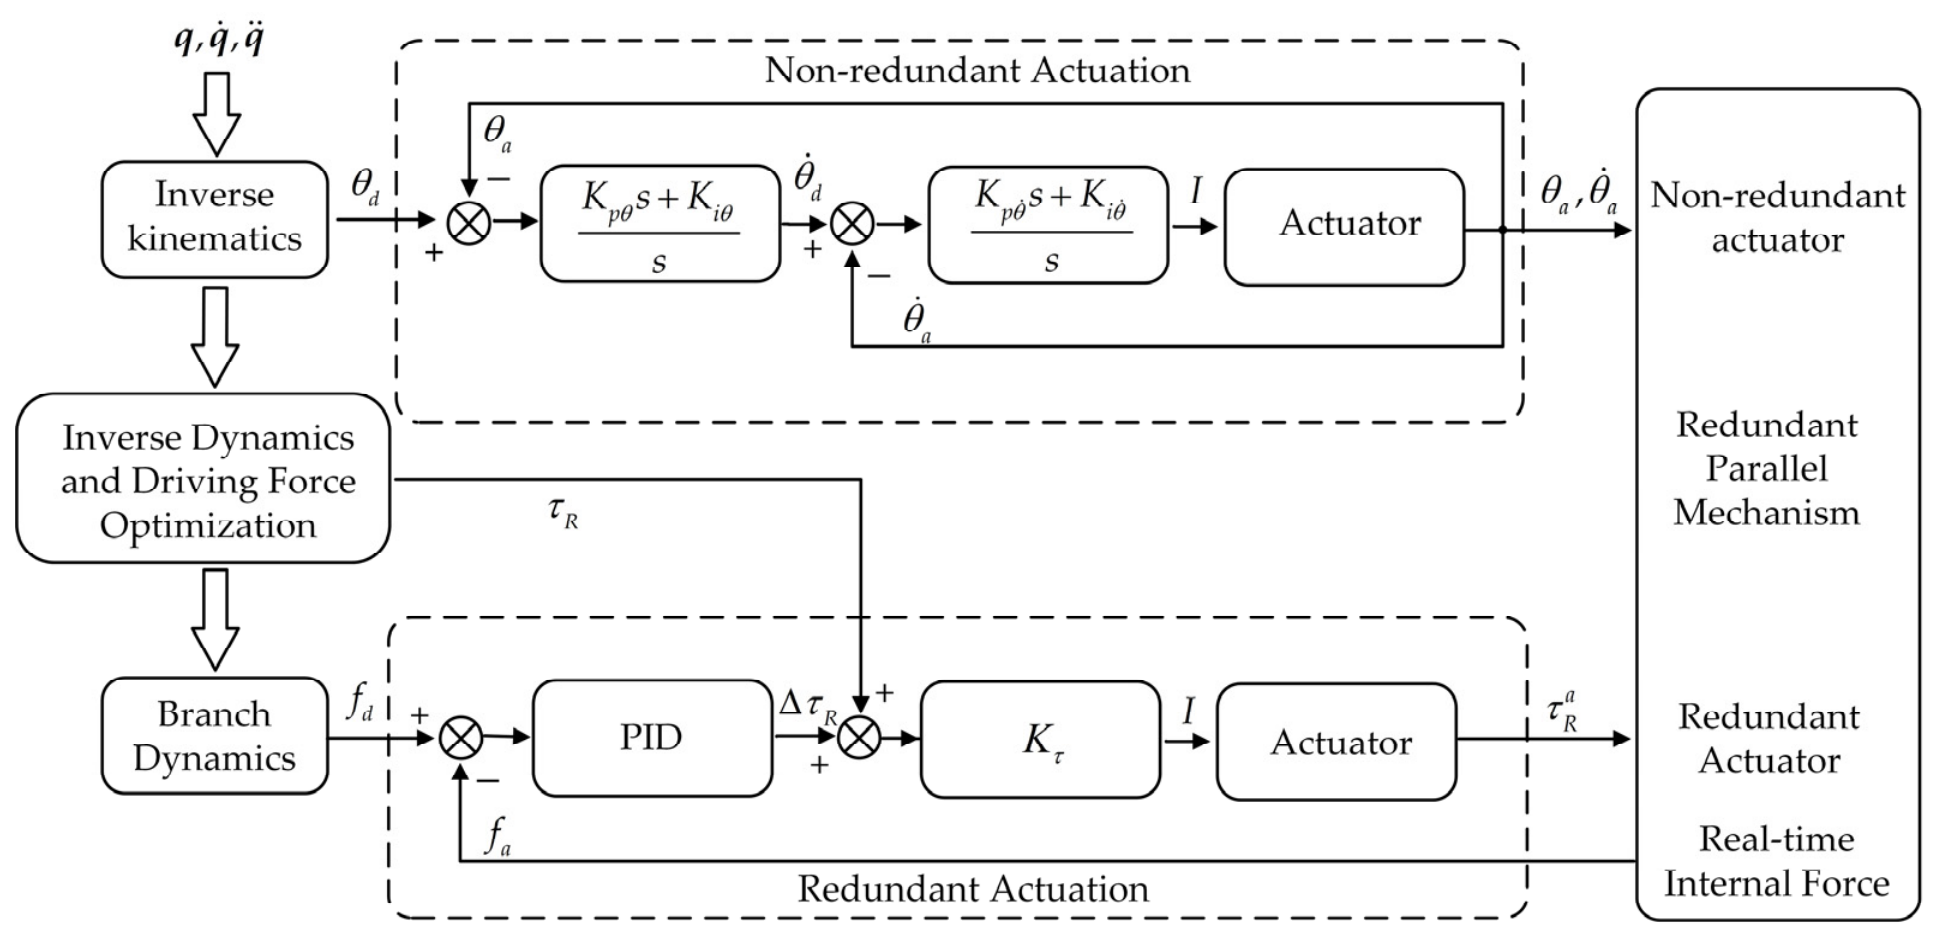
Figure 5 illustrates the active internal force control for a system with n end-effector degrees of freedom, m actuated pairs m(m > n) and r redundant actuated pairs. Herein, θ d = θ d 1 , θ d 2 , , θ d n T denotes the preset position command under the non-redundant actuation mode, and θ ˙ d = θ ˙ d 1 , θ ˙ d 2 , , θ ˙ d n T represents the corresponding preset velocity command. θ a = θ a 1 , θ a 2 , , θ a n T stands for the actual position feedback, while θ ˙ a = θ ˙ a 1 , θ ˙ a 2 , , θ ˙ a n T is the measured velocity information. τ R = τ R 1 , τ R 2 , , τ R r T is the basic driving force obtained via inverse kinematics and driving force optimization. f d = f d 1 , f d 2 , , f d r T refers to the preset internal force of each branch, and f a = f a 1 , f a 2 , , f a r T is the actual internal force measured by the internal force sensors of the robot. In this control framework, fd takes the same numerical value as the corresponding components of τR, serving as the setpoint for the closed-loop force tracking loop, while τR acts as the open-loop feedforward command.
As shown in Figure 5, the active internal force regulation strategy first takes the end trajectory of the robot as the initial input. The desired positions θ d of actuators under the non-redundant actuation mode are calculated via inverse kinematics, which are then used as the position control commands.
G p s = K p θ s + K i θ s G v s = K p v s + K i v s G f s = K p f + K i f s + K d f s
In the formula, G p s denotes the transfer function of the position loop controller, and G v s represents the transfer function of the velocity loop controller. K p θ is the proportional gain and K i θ is the integral gain of the position loop. K p v is the proportional gain and K i v is the integral gain of the velocity loop. s is the Laplace operator, a standard symbol in continuous control that represents differential and integral operations. Symbols for the velocity loop follow the same definition. G f s refers to the transfer function of the internal force loop controller. Correspondingly, Kpf, Kif and Kdf are the proportional gain, integral gain and derivative gain of the internal force loop respectively. K τ is the drive amplification coefficient, which is a fixed physical parameter determined directly by the armature resistance and torque constant of the motor. I denotes an integral element with a 1/s transfer function, which represents the motion-mapping relationship that obtains position or displacement by integrating velocity. For torque-related signal commands, internal fast servo drive dynamics are required to convert them into velocity signals before entering this module, so as to realize the integral-based control architecture. Each branch adopts a ball-screw linear actuator driven by a servo motor. The specific dynamic description is given by the following formula.
J m θ ¨ m + B m θ ˙ m = τ m K f F ,       x = P / 2 π θ m ,       τ m = K τ τ R + Δ τ R
where Jm is the equivalent inertia reflected to motor shaft, Bm is viscous damping, τm is motor output torque, Kf is torque–force conversion coefficient, F is actuator axial force, and P is ball-screw lead. The drive amplification coefficient Kτ maps outer-loop control outputs to servo torque references, which is calculated from motor torque constant, armature resistance, ball-screw lead and transmission efficiency. The high-bandwidth inner current–torque loop of servo drives is omitted in Figure 5 to highlight the outer-loop force–position hybrid control architecture.
Non-redundant actuation adopts dual-loop control consisting of a position loop and a velocity loop. The position deviation e θ = θ d θ a is fed into the position loop controller Gp(s), which outputs the desired branch velocity θ ˙ d . The velocity error e θ ˙ = θ ˙ d θ ˙ a is then transmitted to the velocity loop controller Gv(s) to generate control current or voltage commands. For redundant actuation, the inverse dynamic calculation is performed based on the robot end-effector trajectory to obtain the basic driving force, which is further optimized. The preset target internal force fd is derived via branch dynamic analysis. The internal force error e f = f d f a is sent to the PID controller to produce the internal force compensation value. The basic driving force and compensation value are summed to obtain the final drive command. After being adjusted by the amplification coefficient, the command is transmitted through the actuators to the driving joints.
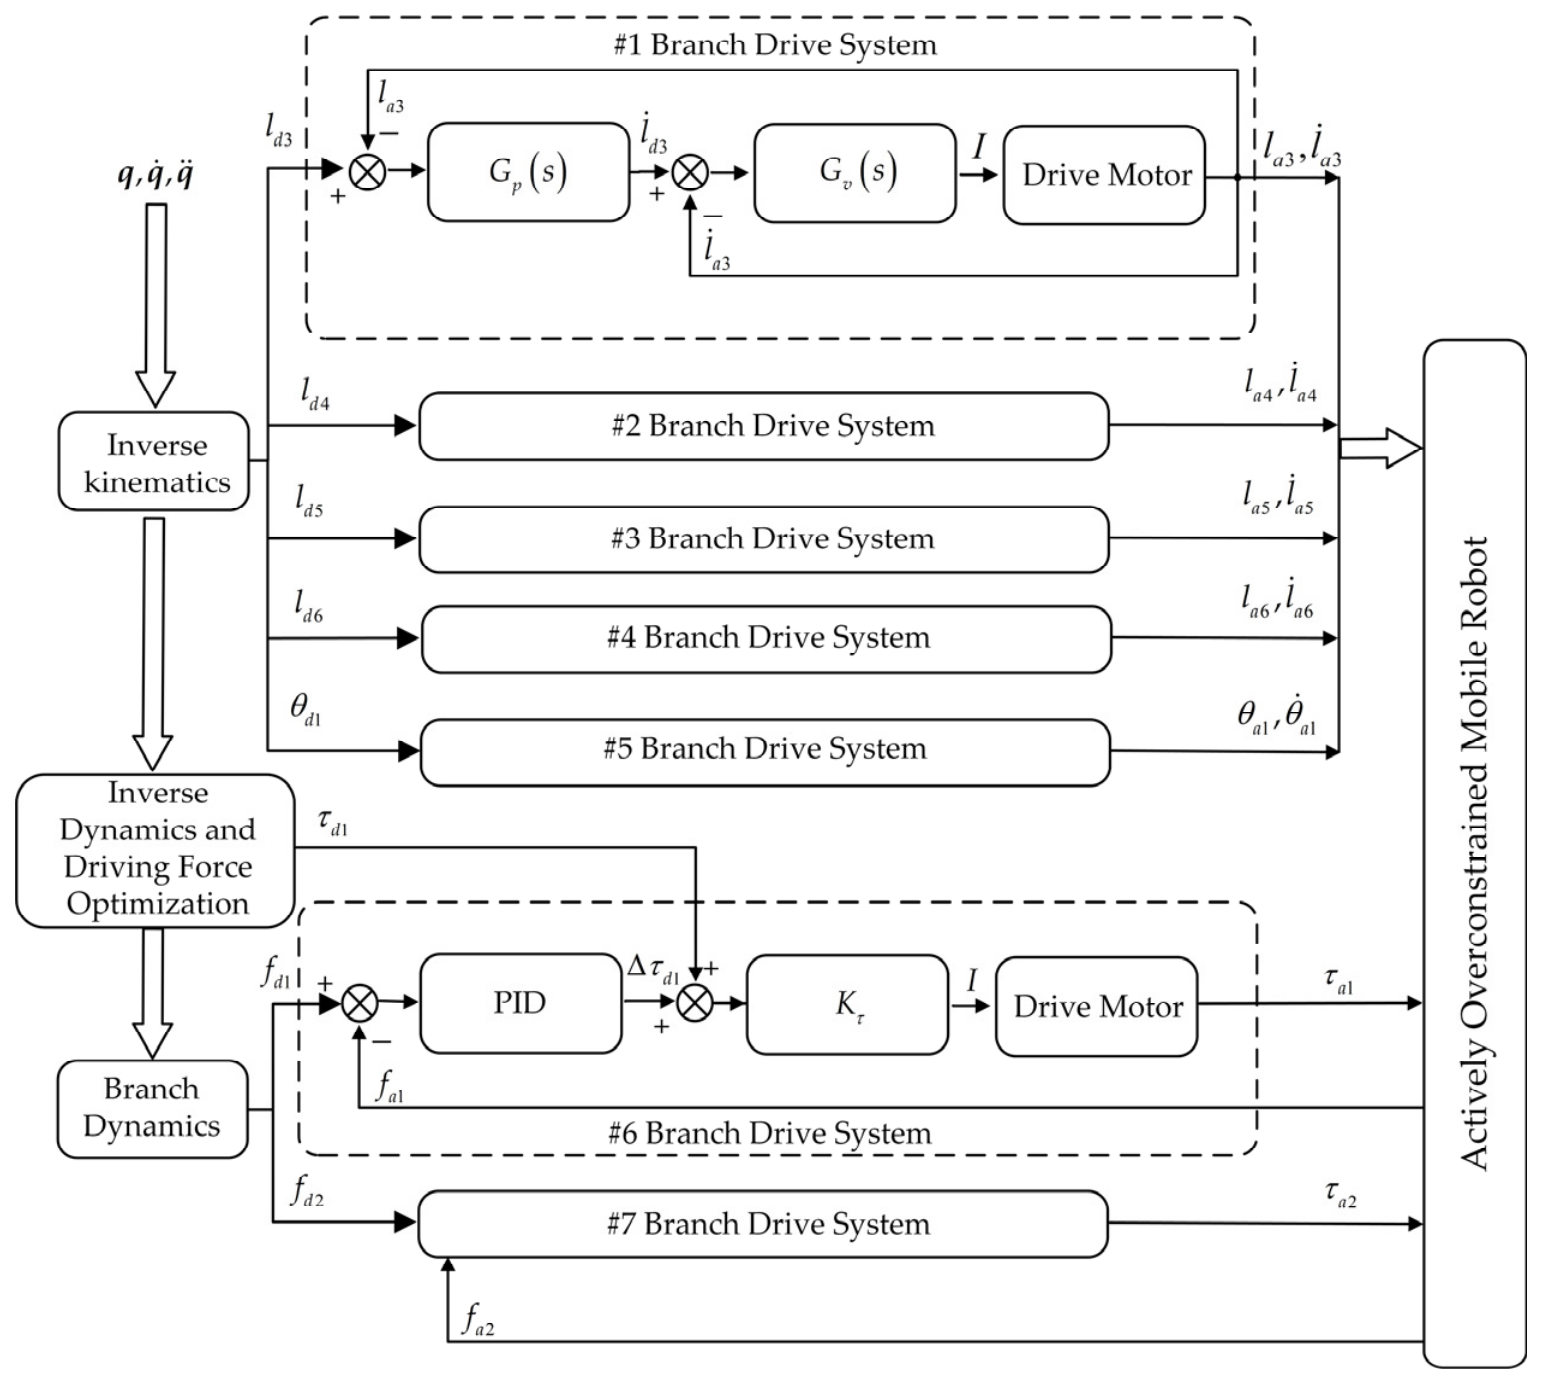
For the mobile robot operating in Mode I under redundant state, the upper platform possesses five degrees of freedom. It is driven by six link branches and one rotary motor. For convenience of description, the driving rods l3l6 of the robot are defined as the #1–#4 branch driving systems, the rotation angle θ1 as the #5 branch driving system, and the two RPR branch chains l1 and l2 as the #6 and #7 branch driving systems. Accordingly, based on the above analysis, Branches #1–#5 are selected as non-redundant driving branches adopting position-driven mode, while Branches #6–#7 serve as redundant driving branches with force-driven mode. Force sensors are mounted on branches l1 and l2 to conduct real-time force detection. The detailed active internal force regulation strategy of the robot is illustrated in Figure 6. During motion, the internal force of the mechanism is affected by position, real-time velocity, acceleration, and active driving force. Hence, the active internal force regulation strategy is applied to feed back and dynamically adjust the real-time internal force of key components, which greatly improves the coordination among all actuators of the redundantly actuated parallel mechanism. The combined position and force regulation realizes compliant interaction between the robot and the external environment as well as among internal components.

4.2. Driving Force Synchronous Coordination Control Strategy

To achieve compliant coordination for the parallel mobile robot under the redundant actuation mode, coordination is required not only between the robot and the external environment, but also among its internal modules. Traditional control methods for driving joints operate each joint independently, resulting in poor coordination across actuators. For the three-platform parallel-coupled mobile robot proposed in this paper, the upper platform has five degrees of freedom under Mode I, while seven active actuators are configured. This leads to redundant actuation and forms a system with strong internal coupling.
The concept of synchronous control was initially applied to the simultaneous control of two motors. By comparing their real-time position, velocity, and acceleration, deviation coupling calculation is performed on these parameters to adjust the operating states of the two motors and achieve synchronous operation. To date, most research on synchronous control focuses on position accuracy, while studies on multi-actuator compliant coordination for redundantly actuated parallel mechanisms remain limited. Accordingly, this section proposes a synchronous coordination control strategy based on the synchronous principle combined with position–force hybrid actuation. The actual driving force of position-controlled actuators is fed back in a closed loop to regulate force-controlled actuators, so as to improve the coordination among components and the overall mechanical performance of the parallel mechanism. For a parallel mechanism with n degrees of freedom and m actuators, the number of redundant actuators is r = mn. Consistent with the active force actuation mode, n actuators are configured for position control and the remaining r for force control. Differently, the real-time driving force of position-controlled actuators is collected and fed back to force-controlled actuators for dynamic force regulation. The detailed synchronous coordination control strategy for the redundantly actuated robot is presented in Figure 7.
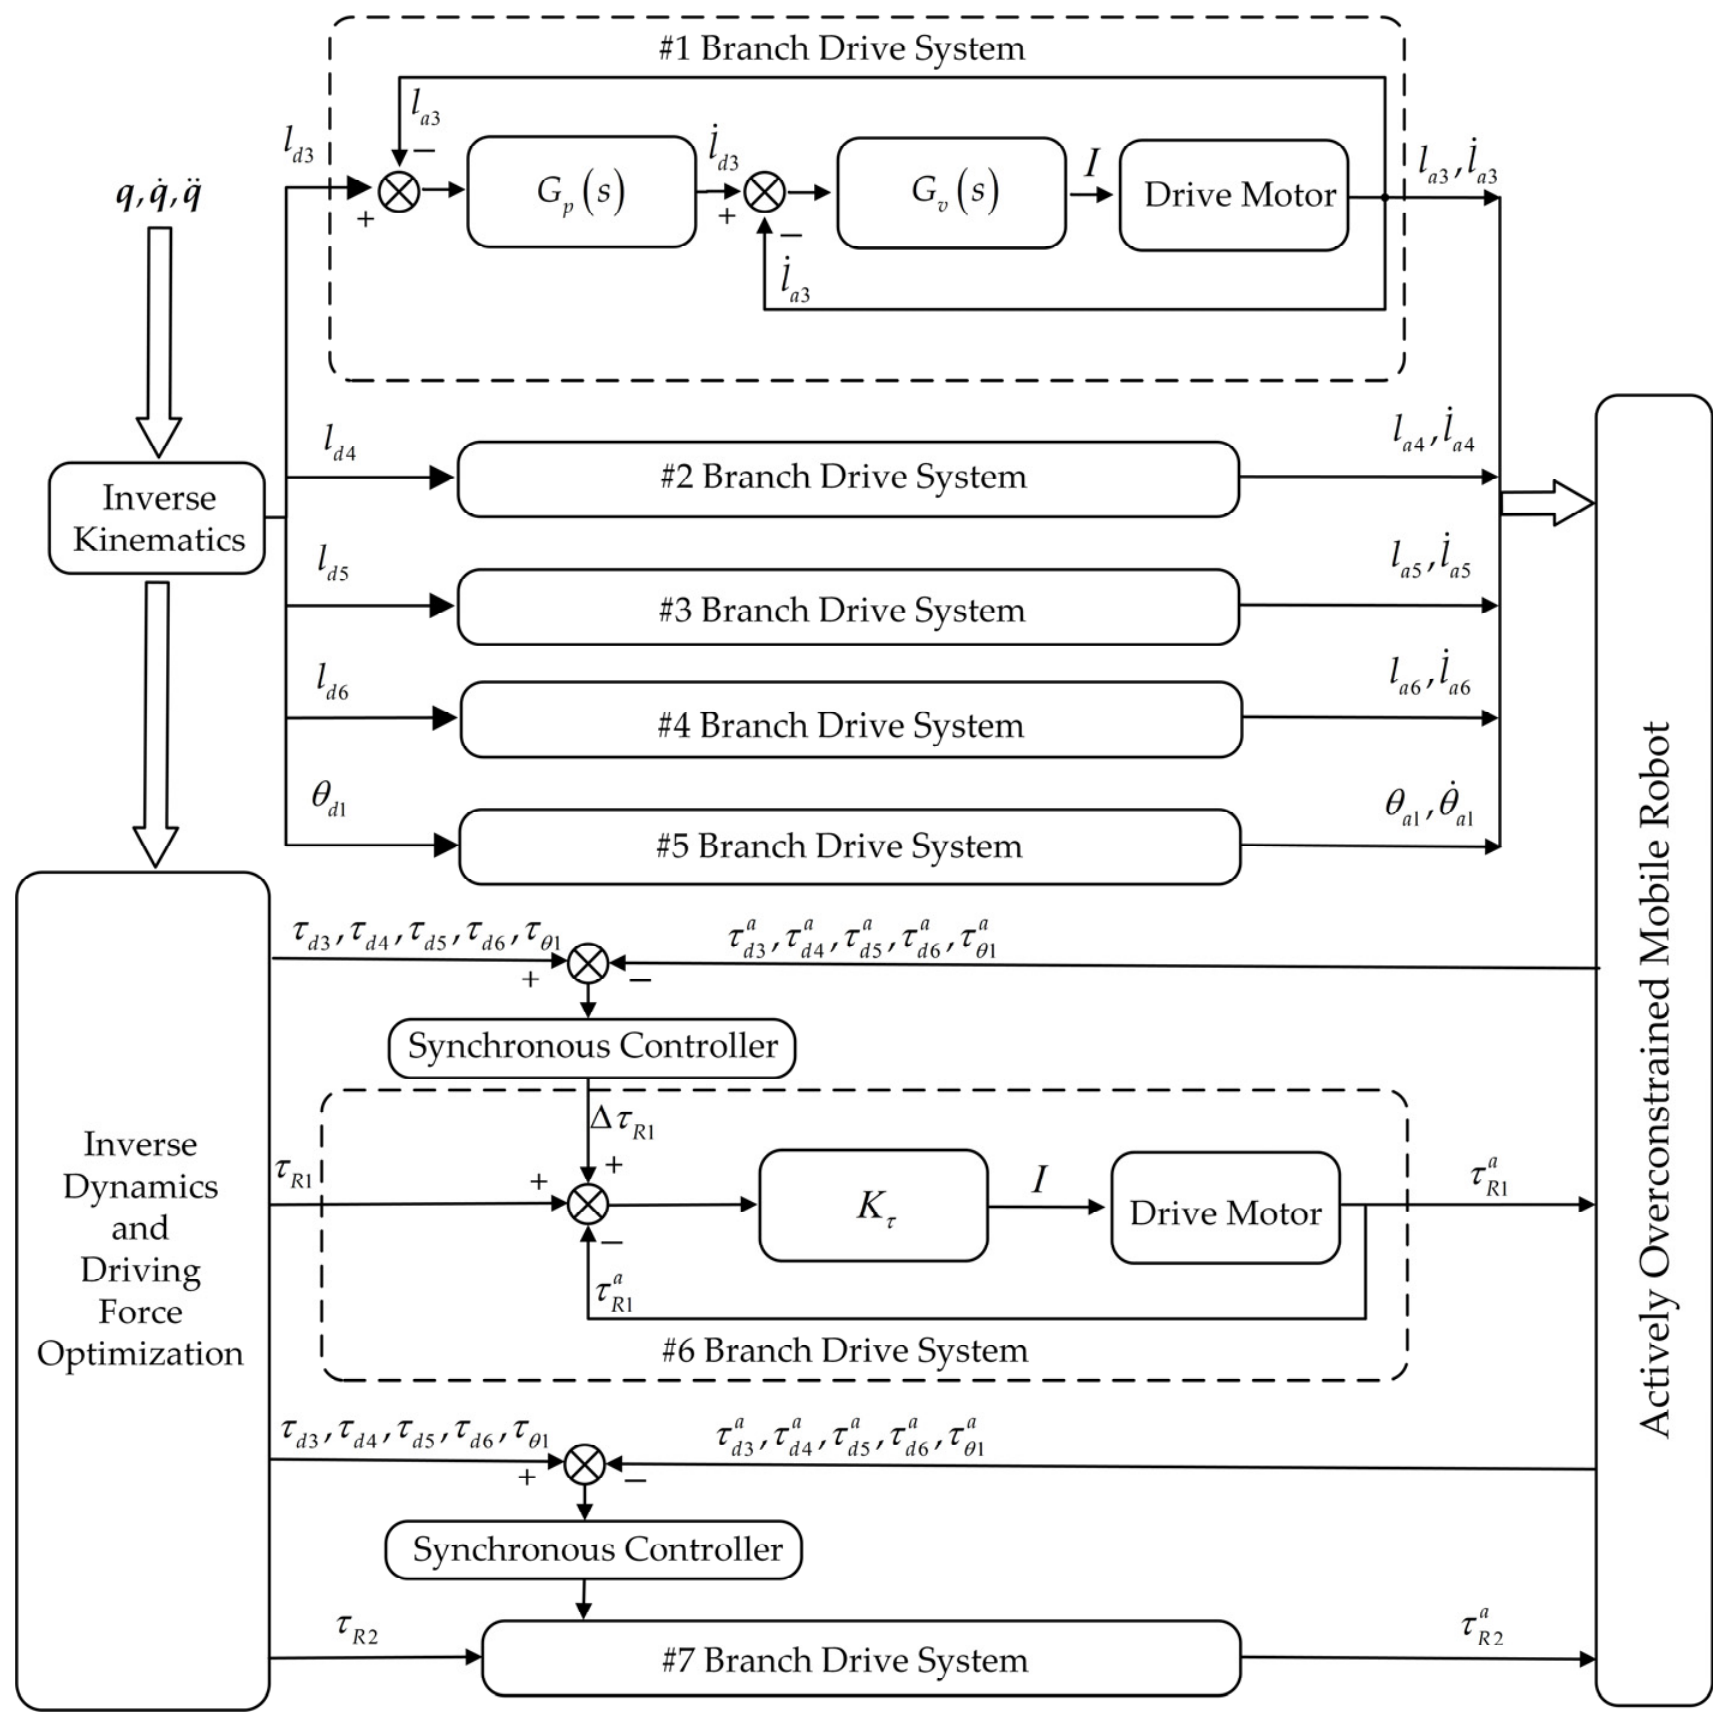
According to the synchronous coordination control strategy shown in Figure 7, the preset desired posture q , q ˙ , q ¨ is taken as the initial input. The corresponding position commands θ d for actuators are obtained via inverse kinematics. Here, θ d covers the drives of four UPS branches and the rotational drive of the R-joint link. The function of non-redundant drive units is identical to that of the non-redundant module in the active internal force regulation strategy. The initial desired force vector of all actuators is calculated by inverse dynamics. The desired driving forces of two RPR redundant branches are extracted and denoted as τ R to serve as feedforward commands. Meanwhile, the driving forces of non-redundant Branches #1–#5 are collected and marked as τ i , which acts as the reference initial driving force. τ i a represents the feedback value of the actual driving force of non-redundant drives, and the force error is acquired by comparison between the two.
e i = τ i τ i a ,         i = 1 , 2 , , n
The non-redundant and redundant components in the redundant driving force model, Equation (31), are separated as follows:
J d T τ d + J R T τ R = τ r e q
In the formula, term τ d R 5 denotes the extracted non-redundant driving force vector, and term τ R R 2 represents the extracted redundant driving force vector. Terms J d R 5 × 5 and J R R 2 × 5 are the corresponding force Jacobian matrices respectively, while term τ r e q = M r q ¨ + C r q ˙ + G r refers to the total generalized force for the desired motion mentioned above. When the parallel mechanism is in a non-singular state, term J d is an invertible matrix. Thus, we can obtain:
τ d = J d T τ r e q J R T τ R
Thus, the mapping relationship between the deviation of non-redundant drives and that of redundant drives can be derived.
Δ τ d = J d T J R T Δ τ R = K c Δ τ R
In the formula, term K c = J d T J R T R 5 × 2 denotes the driving force coordination matrix. The force coordination relation in Equation (38) is superimposed on the force deviation between the desired and actual values of non-redundant drives to obtain term e d + Δ τ d = e d K c Δ τ R . To minimize the coordinated force error and achieve reasonable energy control, a quadratic performance index is established as follows:
J p = 1 2 e d K c Δ τ R T W e e d K c Δ τ R + Δ τ R T W u Δ τ R
In the formula, term W e R 5 × 5 is the weighting matrix of force error and term W u R 2 × 2 is the weighting matrix for energy control, both of which are positive definite diagonal matrices. Let term J p / Δ τ R = 0 , then the optimal synchronous coordination solution can be derived as follows:
Δ τ R = K c T W e K c + W u 1 K c T W e · e d = K s y n c · e d
In the formula, term K s y n c R 2 × 5 is the synchronous coordination matrix, which can be calculated from the force coordination matrix Kc and weighting matrices in each control cycle.
This control method is applied to the redundantly actuated mobile robot in this research. Branches #1–#5 are still selected as non-redundant driving branches with position control, while Branches #6–#7 are adopted as redundant driving branches with force control. Based on the above analysis, a synchronous controller is designed. It collects real-time force data from Branches #1–#5 and processes the data. The synchronous control algorithm is utilized to realize real-time regulation of the redundant Branches #6 and #7. The detailed synchronous coordination control strategy of the robot is shown in Figure 8.
The driving errors of the robot are calculated via coupling operation to form the proposed synchronous coordination control strategy. The strategy directly acquires and feeds back the force errors of all actuators, and the synchronous controller outputs the adjustment deviations for force-controlled actuators. In this way, the actuators in the redundant drive system no longer work independently. Optimal driving forces are obtained through information feedback and optimization calculation, enabling all actuators to operate as a coordinated and interactive whole. Analogous to a coordinated multi-agent system, the robot realizes information sharing among individual units, mitigates internal uncoordinated behaviors, reduces internal energy consumption, and achieves compliant interaction among different components.

5. Neural Network-Based Force–Position Hybrid Control Algorithm

Collaborative robots emphasize information interaction and cooperative operation between robots, as well as between robots and the environment. The three-platform parallel-coupled mobile robot studied in this paper is equipped with multiple supporting branches that exhibit strong force coupling effects. Neural networks feature excellent nonlinear mapping and self-learning capabilities, and can adjust parameters according to real-time environmental conditions, making them an effective tool for improving the collaborative performance of mobile robots. Especially for redundantly actuated parallel mechanisms, the control design involves numerous variable parameters, which well matches the multi-input and multi-output characteristics of neural networks.

5.1. Neural Network Active Internal Force Control Algorithm

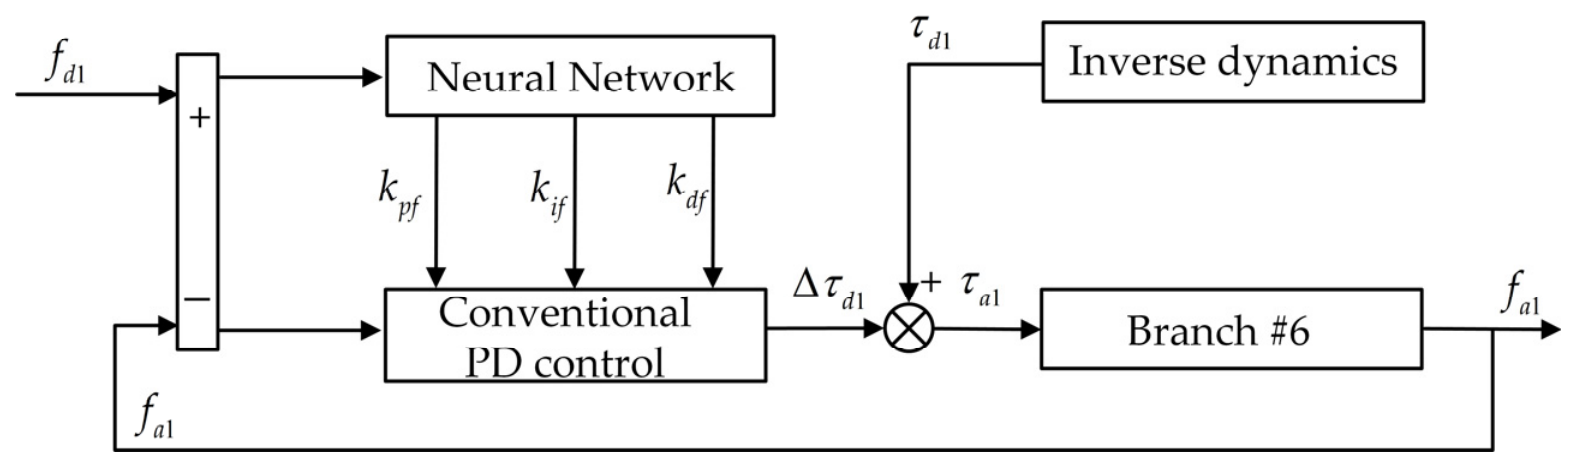
Combined with the neural network optimization method, an active internal force regulation algorithm with self-tuning parameters is established on the basis of the aforementioned active internal force regulation strategy for redundantly actuated parallel mechanisms. There are two redundant driving branches in this research. The neural network structure is designed for one branch first, and the other branch follows the same design principle, as illustrated in Figure 9. The proposed composite controller consists of two functional modules. The first module adopts conventional PID control as the feedforward and feedback loop to realize closed-loop control of the redundant driving branch. The second module utilizes a neural network to regulate the control loop. By monitoring real-time internal force errors and capturing their dynamic variations, the network adaptively optimizes the proportional and differential gains of the PID controller, so as to achieve the global optimal control performance.
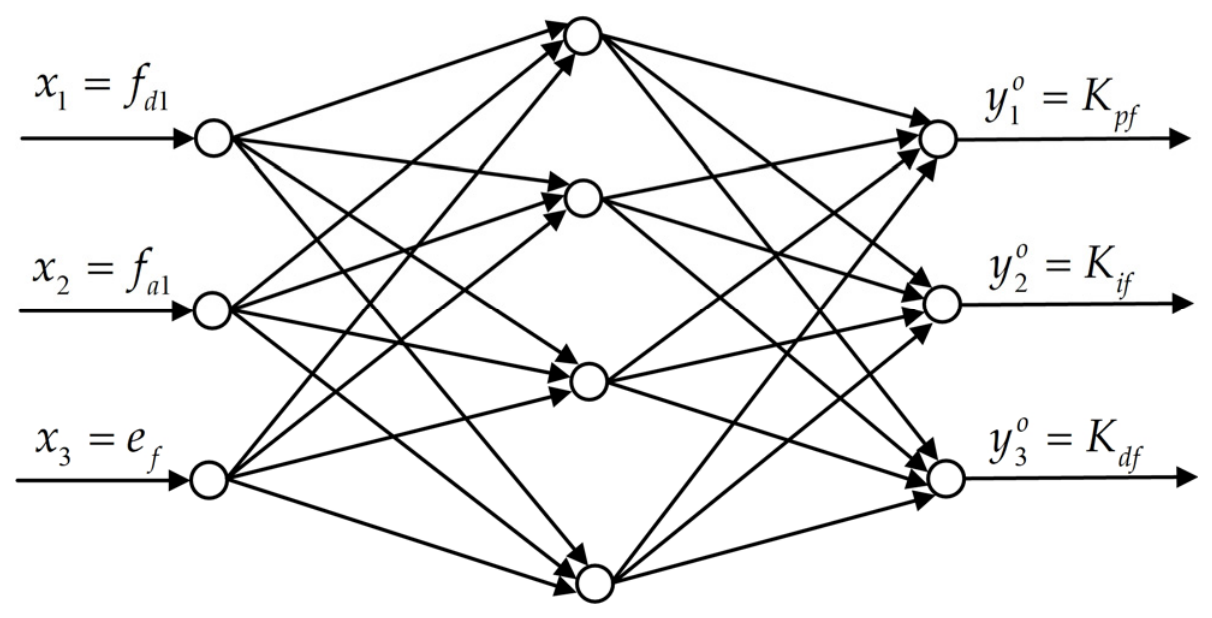
Since optimizing the proportional gain Kpf, integral gain Kif and differential gain Kdf of the conventional PID controller can effectively improve the control performance, an adaptive parameter tuning strategy based on BP neural network is adopted herein. The specific network topology is shown in Figure 10.
Taking branch A1C1 as the redundant driving branch l1, a neural network-based PID controller shown in Figure 9 is designed for its active internal force control system. The detailed internal structure of the neural network is presented in Figure 10.
The output layer contains three nodes, and the input is x = x 1 , x 2 , x 3 T . Herein, x 1 = f d 1 , x 2 = f a 1 , x 3 = e f = f d 1 f a 1 and f d 1 represent the preset desired internal forces of the redundant driving branch l1, which are calculated from the desired trajectory using the inverse dynamics Equations (26) and (27) mentioned above. f a 1 stands for the actual value measured by the force sensor mounted on the connecting rod, and e f denotes the error between the actual and desired internal forces. The hidden layer adopts four nodes with the hyperbolic tangent function as the activation function. The three nodes in the output layer correspond to the pre-optimized proportional gain, integral gain and differential gain, namely y 1 o = K p f , y 2 o = K i f and y 3 o = K d f . The input–output mapping relationship of the k-th node (k = 1, 2, 3, 4) in the hidden layer is expressed as follows:
υ k h = i = 1 3 w k i h x i ,         y k h = φ k h υ k h
The input and output of the j-th node (j = 1, 2, 3) in the output layer are given as follows:
υ j o = k = 1 4 w j k o y k h ,         y j o = φ j o υ j o
In the formula, w k i h denotes the weight from the i-th node of the input layer to the k-th node of the hidden layer, and w j k o represents the weight from the k-th node of the hidden layer to the j-th node of the output layer. The adjustment quantity of the driving force for redundant branch l1 output by the controller is defined as term Δ τ d 1 , which is expressed as:
Δ τ d 1 = K p f e f + K i f 0 t e f d τ + K d f e ˙ f
The final actual driving force applied to the redundant driving branch is the sum of the desired force and the adjustment quantity.
τ d 1 a c t = τ d 1 f f + Δ τ d 1
In the formula, term τ d 1 f f is the open-loop feedforward force calculated by the generalized inverse dynamics in Equation (33).
The concrete BP network adopts an online-learning scheme without offline pre-training. Its optimization objective is half of the sum of squares of the current internal force errors. Weight updating employs the negative-gradient search method with an inertial term. Specifically, weights are corrected along the descending direction of the error function in each iteration. A fixed proportion of the previous update quantity is superimposed in every iteration to smooth the updating process. The learning rate is fixed at 0.01 and the inertial coefficient is set to 0.9. Weights are randomly initialized within the range of [−0.5, 0.5]. The real-time control period of the system is 1 ms; hence, all parameters are refreshed in every control cycle. During error back-propagation, the gain between the input and output of the controlled plant, i.e., the partial derivative of the internal force error with respect to the control increment, is approximated by a sign function. This guarantees the robustness of the algorithm under unknown loads. The above-mentioned learning rate is determined through repeated simulations to balance the convergence speed and oscillation suppression. Rigorous stability derivation based on Lyapunov analysis is beyond the scope of the present work. Therefore, the boundedness of closed-loop signals under fast transient conditions is verified via simulation and experimental observations, whereas formal Lyapunov-based stability analysis will be addressed in future investigations.
Through continuous online learning, the neural network dynamically tunes Kpf, Kif, and Kdf according to the current internal force error as well as its integral and differential values. Consequently, the robot achieves high-precision internal force control under various configurations and loads. This fully reflects the self-adaptive regulation capability of the robot’s internal force state, and serves as an essential foundation for realizing human–robot–environment collaboration.

5.2. Neural Network Synchronous Coordination Control Algorithm

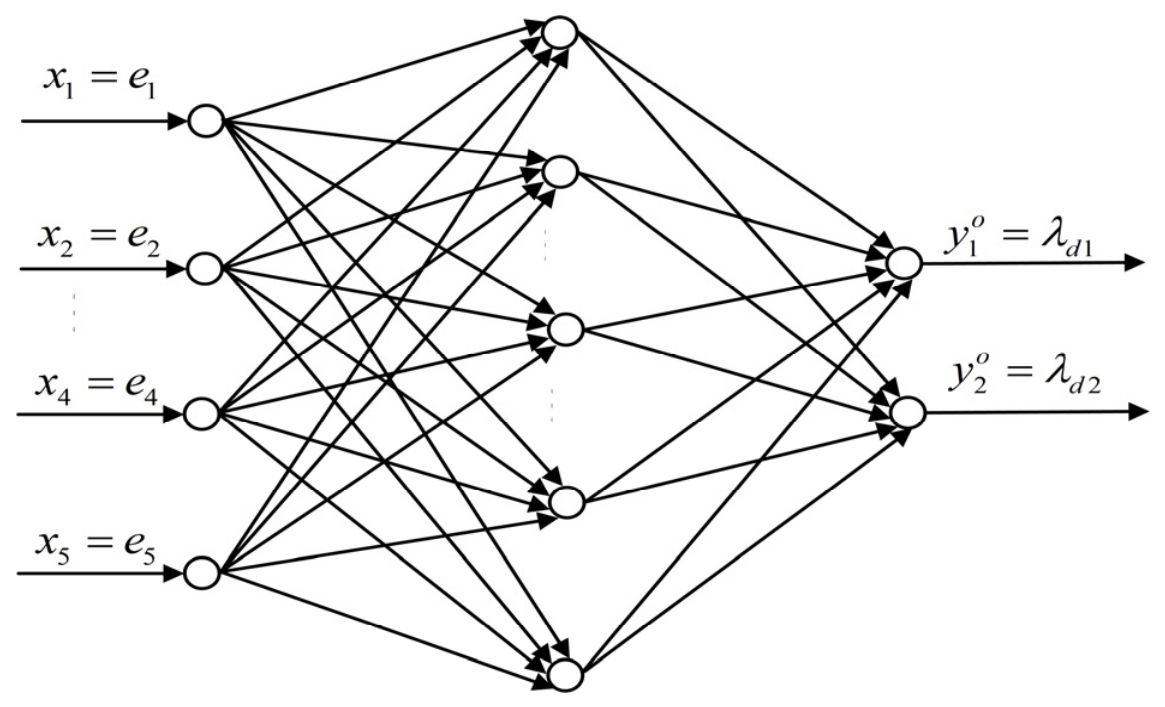
Although the parameter optimization and control performance of traditional PID closed-loop control are greatly improved after combining with intelligent algorithms, its fixed single-output structure limits the analysis of multi-source state signals. Redundantly actuated parallel mechanisms are strongly coupled and multivariable systems, which require synchronous signal processing for multiple branches. Meanwhile, it is necessary to guarantee the control accuracy of each individual branch as well as the coordination consistency among all branches. Accordingly, this section takes advantage of the multi-dimensional characteristics of neural networks to design a dynamic synchronous coordination controller. By fusing various signals to make comprehensive decisions, the synchronization and overall control accuracy of each branch of the redundantly actuated parallel mechanism are enhanced. The mobile robot in this study adopts a redundant control mode with seven actuators. The structure of the neural network-based synchronous coordination controller is shown in Figure 11.
Considering the characteristics of the mobile robot, the number of nodes in the input layer of the neural network-based synchronous coordination controller is equal to the total number of driving branches of the robot, i.e., n = 5. The input vector is defined as e = [e1, e2, e3, e4, e5]T, where
e i = τ i d e s τ i a c t ,   i = 1 , 2 , , 5
Since the superscripts d, θ and R are used for forces in this structure, all forces are expressed uniformly with the symbols in the above formula. For the four position-driven branches and one angular branch, the corresponding τ i d e s can be obtained via inverse dynamics. τ i a c t is measured by actual motors. Similarly, the relevant values of redundant driving branches l1 and l2 can also be calculated by inverse dynamics. The hidden layer is configured with 10 nodes, and the hyperbolic tangent function is adopted as the activation function. The number of output layer nodes is set to r = 2, corresponding to the number of redundant drives of the mechanism. The weighting coefficients for the driving force adjustment of each redundant branch are defined as:
y 1 o = λ d 1 ,         y 2 o = λ d 2
In the formula, λ d 1   and λ d 2 denote the weighting coefficients corresponding to redundant branches l1 and l2 respectively. The final driving force adjustments of l1 and l2 are calculated by the following formulas.
Δ τ d 1 = λ d 1 i = 1 5 K s y n c , 1 i e i ,         Δ τ d 2 = λ d 2 i = 1 5 K s y n c , 2 i e i
It should be noted that the synchronization–coordination matrix Ksync in the above equation is derived from the force Jacobian matrix of the parallel mechanism. Its constituent elements already contain the appropriate physical dimensions required for mapping between non-redundant and redundant branches. Therefore, the weighted operation via Ksync converts the linear branches 1–4 and the rotational branch 5 into a unified Newton-force unit. This ensures that the summation can generate physically meaningful correction forces for redundant branches 6 and 7 without manual normalization. Equation (50) herein represents an additional adaptive correction term rather than a replacement for Equation (43). Compared with adopting a full 2 × 5 learnable matrix or directly tuning Ksync online, the gains λd1 and λd2 are more desirable. This is because they preserve the analytical structure and physically interpretable nature of Ksync, while drastically reducing the number of parameters required for online learning.
The actual driving force applied to each redundant branch is expressed as:
τ d 1 a c t = τ d 1 d e s + Δ τ d 1 ,         τ d 2 a c t = τ d 2 d e s + Δ τ d 2
The network training mode here is consistent with that described in Section 5.1, except that the cost function is modified to the sum-of-squared errors of the five driving branches to reflect the synchronization performance of the whole robot. The weight-update rule remains the gradient-descent scheme with an inertial term. The learning rate, inertial coefficient, and control cycle are still (0.01, 0.9, 1 ms), and the initial weights are also randomly initialized within the range of [−0.5, 0.5]. The entire training process is implemented fully online without offline pre-training. During back-propagation, the partial derivative of each branch’s error with respect to the control increment of redundant branches needs to be computed. Consistent with the description in Section 5.1, the identical learning-rate tuning rule and stability considerations also apply to this neural network. With this optimized model, the neural network automatically adjusts the weight ratio of output forces for redundant branches according to the driving force errors of all branches. This keeps the error distribution of all driving branches stable and prevents local overload. The method enables the strongly coupled branches of the robot to achieve group-level collaboration, which fully embodies the concept of multi-actuator coordination and synergistic operation.

6. Experimental Research on Three-Platform Parallel-Coupled Mobile Robot

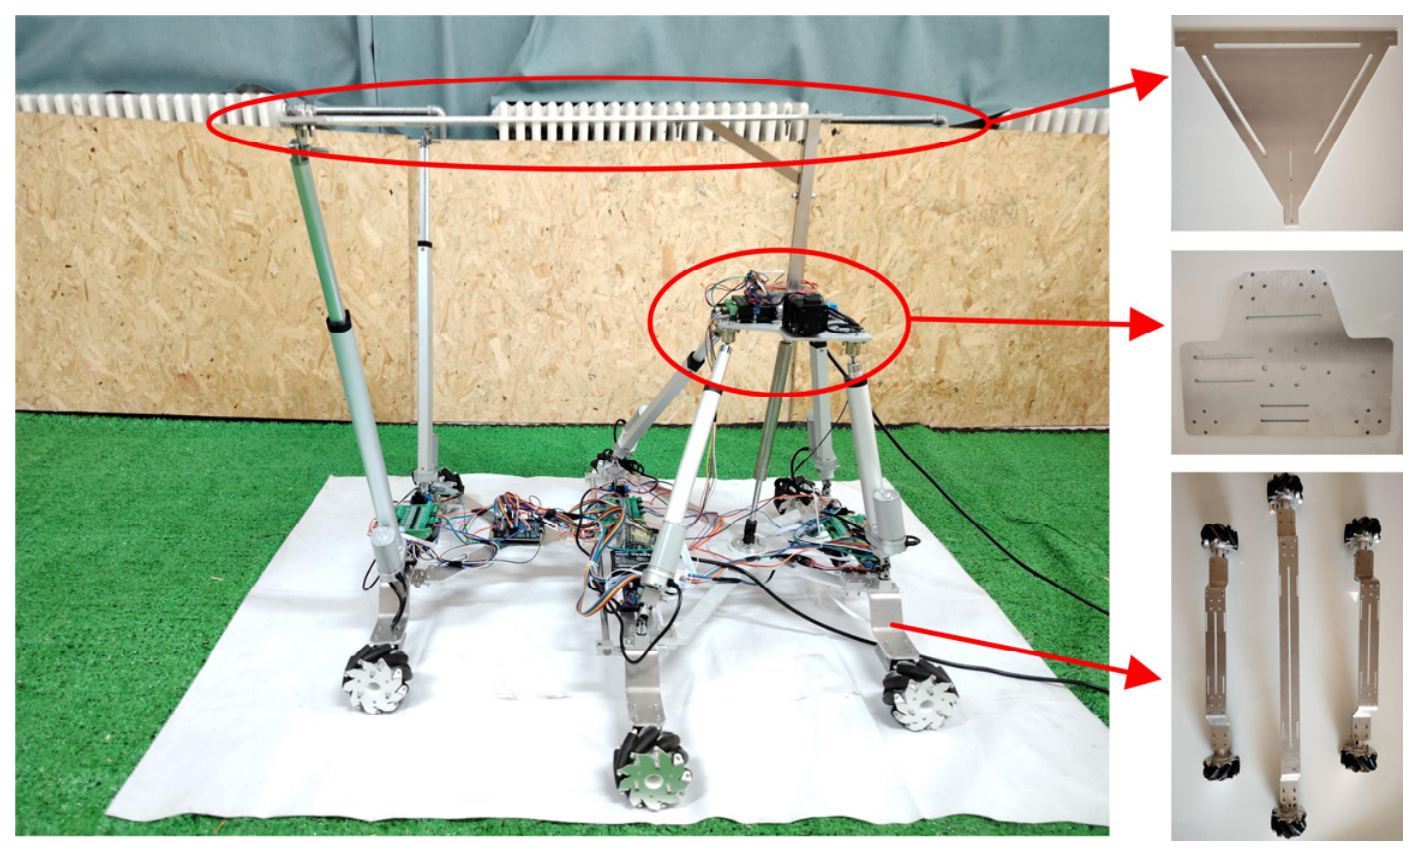
A joint simulation model for the mechatronic control system was established to verify the effectiveness and feasibility of the control strategy. A system dynamics model of a three-platform parallel robot was constructed using ADAMS 2022 simulation software. However, this model is only suitable for simulation analysis of mechanism motion and control under ideal driving input conditions, and it cannot trace the source of control system errors, analyze error characteristics, or study the impact of control algorithms on the overall control performance. To address this issue, a servo drive system simulation model was built using MATLAB R2022a to complete the modeling and programming of high-precision control algorithms. By establishing a data exchange channel between the control model and the Adams dynamics model, a joint simulation platform for the mechatronic control system of the three-platform parallel robot was constructed. At the same time, a mobile robot prototype was designed and manufactured for experimental testing. The physical prototype is shown in Figure 12.
Figure 12 shows the physical prototype of the three-platform coupled mobile robot. The three sub-figures on the right illustrate the upper platform, the middle platform, and the three supports of the lower platform of the robot. Two Mecanum wheels are mounted at both ends of each support; thus, the mobile robot is equipped with six Mecanum wheels in total. The active drives of the robot come from six driving rods connected to the front, middle, and rear supports, as well as the motor mounted on the upper end of the middle platform, yielding seven power sources in total.

6.1. Active Internal Force Control Simulation

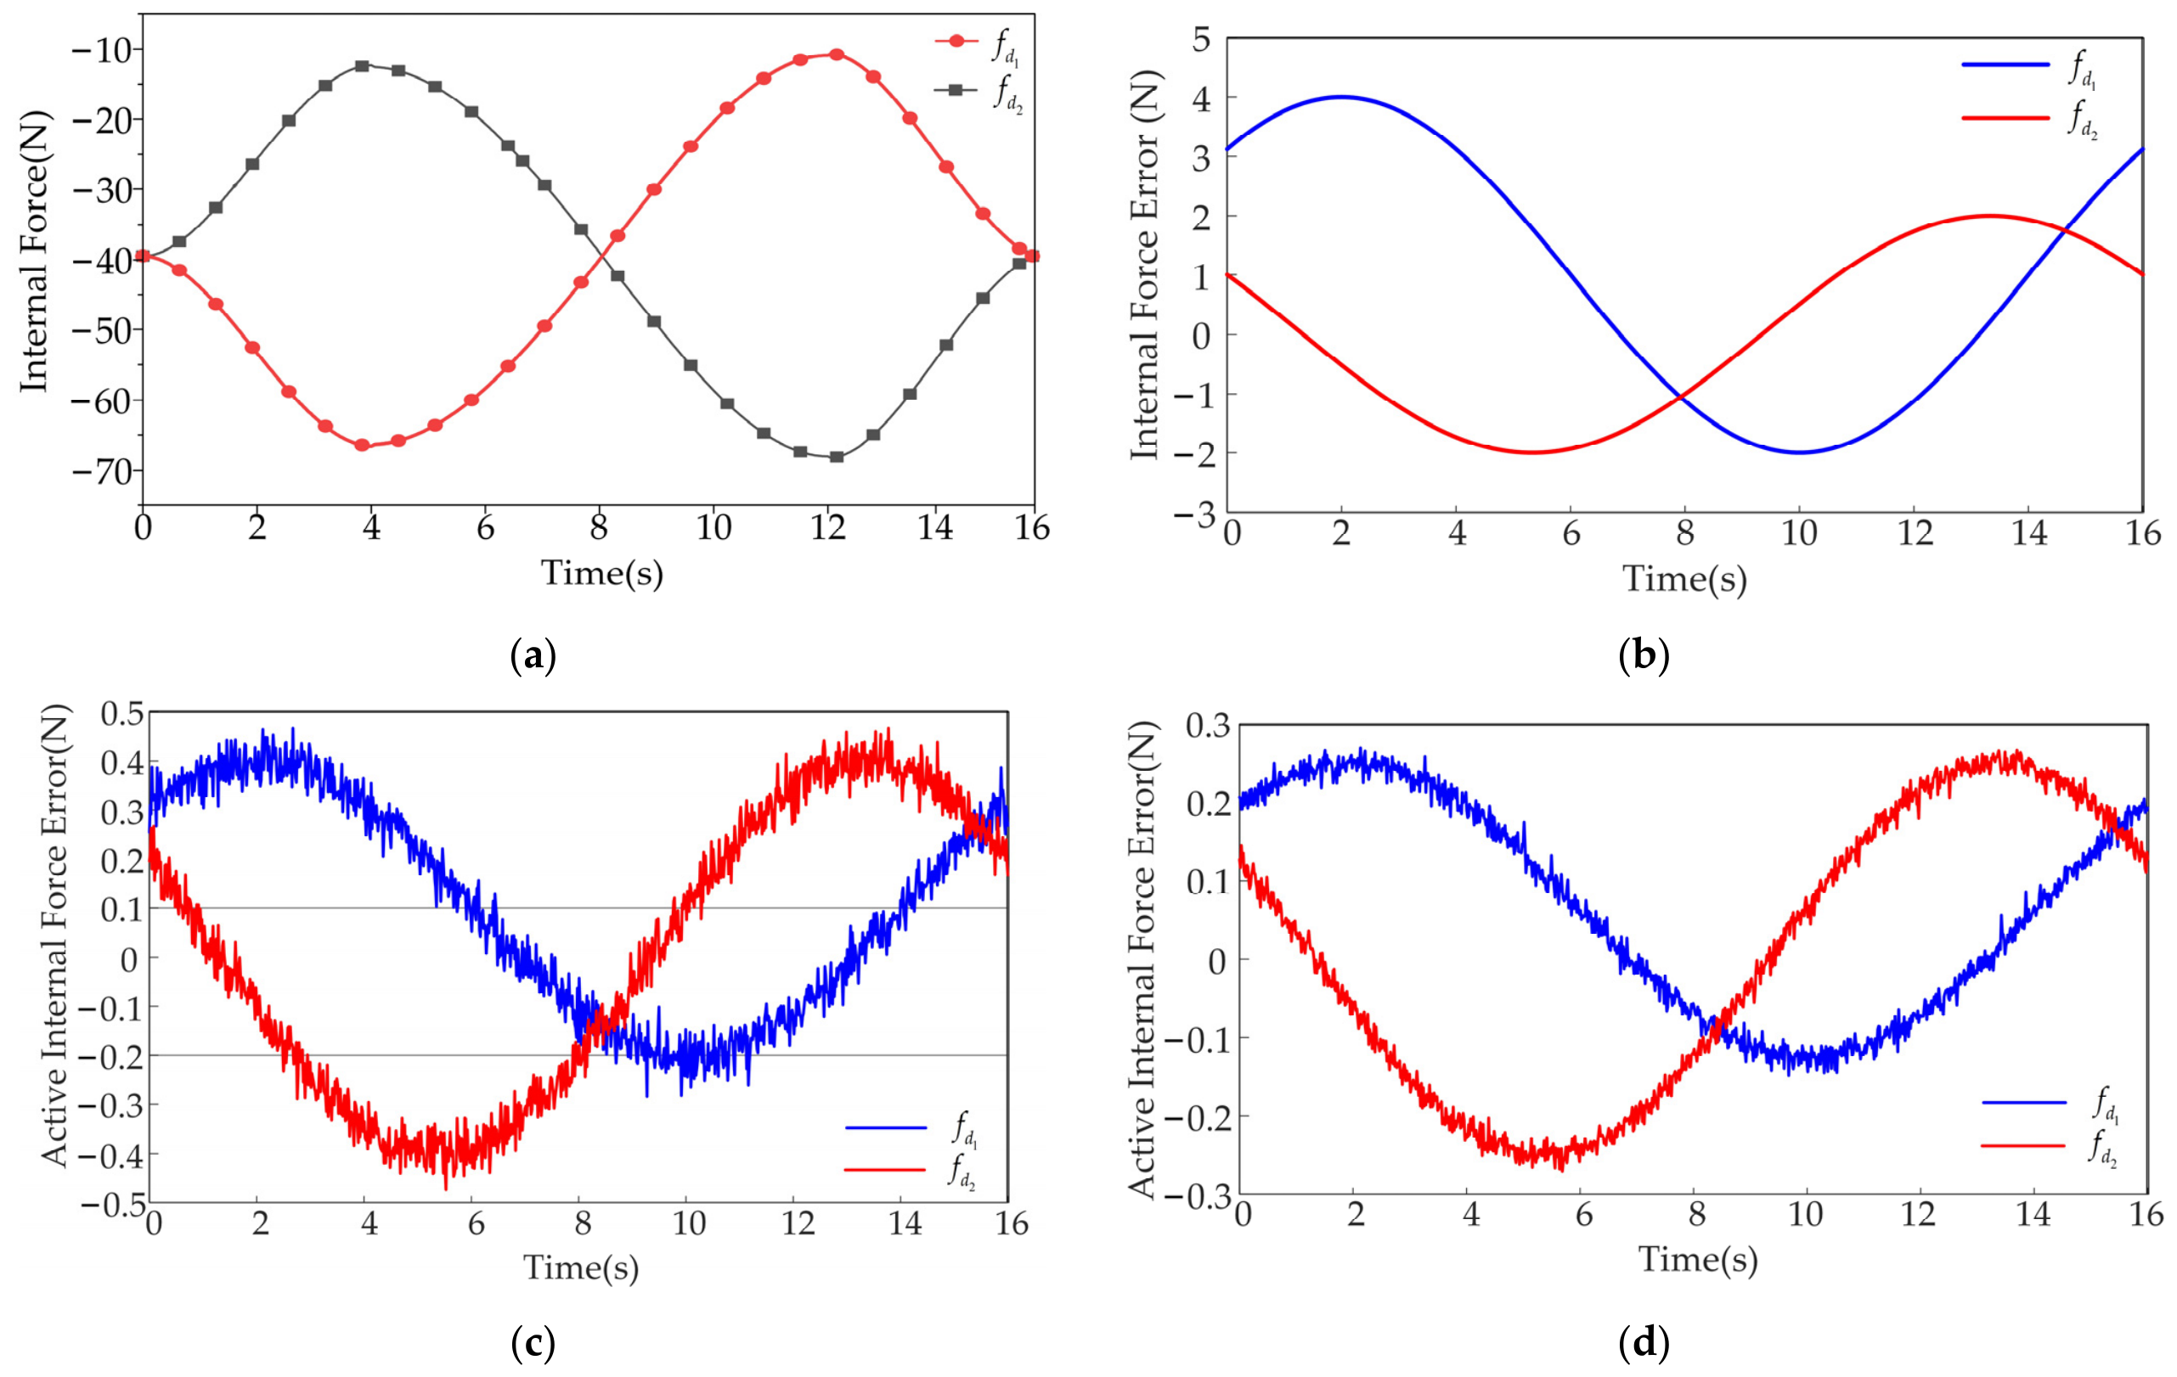
Based on MATLAB, a hybrid drive control system for the redundant driving force and position of a three-platform parallel robot was established. The internal force detection values of the #6 and #7 branch links were fed back to the control system to establish an active internal force control strategy. The simulation trajectory was consistent with the motion trajectory in the mechanism dynamics simulation, and the posture of the moving platform did not change during the motion process, with no singular configuration occurring. The driving position changes of #1 to #5 were calculated based on the inverse kinematics solution of the mechanism; the driving force curves allocated to the #6 and #7 driving rods were calculated based on the mechanism dynamics, and the internal force curves of the links were calculated based on the branch dynamics model, resulting in the internal force curve diagram shown in Figure 13a. Three control strategies, namely the traditional force–position hybrid driving control, active internal force regulation, and neural network-based active internal force control, are adopted to carry out simulation verification and physical prototype experiments for the robot. The internal forces of the #6 and #7 branch links during simulation and experiments are recorded, and their errors relative to the desired internal forces are calculated separately. Multiple experimental validations demonstrate that the error trends between the actual internal forces and the desired internal forces are basically consistent under the three control strategies. To avoid excessive figures in the manuscript, only partial simulation and experimental results are presented. Figure 13b shows the error curve between the actual and desired internal forces under the traditional force–position hybrid control in simulation, and the corresponding experimental results agree well with this simulation result. Figure 13c presents the experimental results under active internal force control, and Figure 13d gives the experimental results optimized by the neural network. In this study, the tracking error is defined as the time-domain deviation between the actual measured value and the desired value at each sampling instant.
Figure 13 presents the expected internal force curve of the connecting rod and the internal force tracking partial error results under three schemes: force–position hybrid control, active internal force control, and neural network optimized active internal force control, as tested on the prototype. As shown in Figure 13b, when only the force–position hybrid drive control is used, the internal force error of the connecting rod exhibits significant periodic oscillations, with an error peak value reaching up to 4 N. After introducing the active internal force regulation strategy, as shown in Figure 13c, the peak value of the internal force error decreases to 0.45 N, representing an 88.4% reduction compared to the original force–position hybrid scheme, significantly suppressing the tracking deviation caused by internal force coupling. On this basis, after introducing neural network adaptive optimization, as shown in Figure 13d, the peak value of the internal force error further decreases to 0.26 N, representing a further 42.22% reduction compared to the active internal force control scheme, and an overall error reduction of 93.5% compared to the initial force–position hybrid control. The high-frequency disturbance in the error curve is also significantly suppressed, verifying the effectiveness of the hierarchical optimization strategy in gradually improving the internal force tracking accuracy. The neural network can adaptively compensate for model uncertainties and residual coupling disturbances, achieving high-precision and stable tracking of the connecting rod’s internal force.

6.2. Driving Force Synchronous Coordination Control Simulation

Similarly, a hybrid drive control system for redundant driving force and position of a three-platform parallel robot is established based on MATLAB. Real-time driving force/torque detection values of Branches #1–#7 are fed back to the control system, and both a drive synchronization and coordination control strategy and a neural network intelligent algorithm-based drive synchronization and coordination control strategy are established.
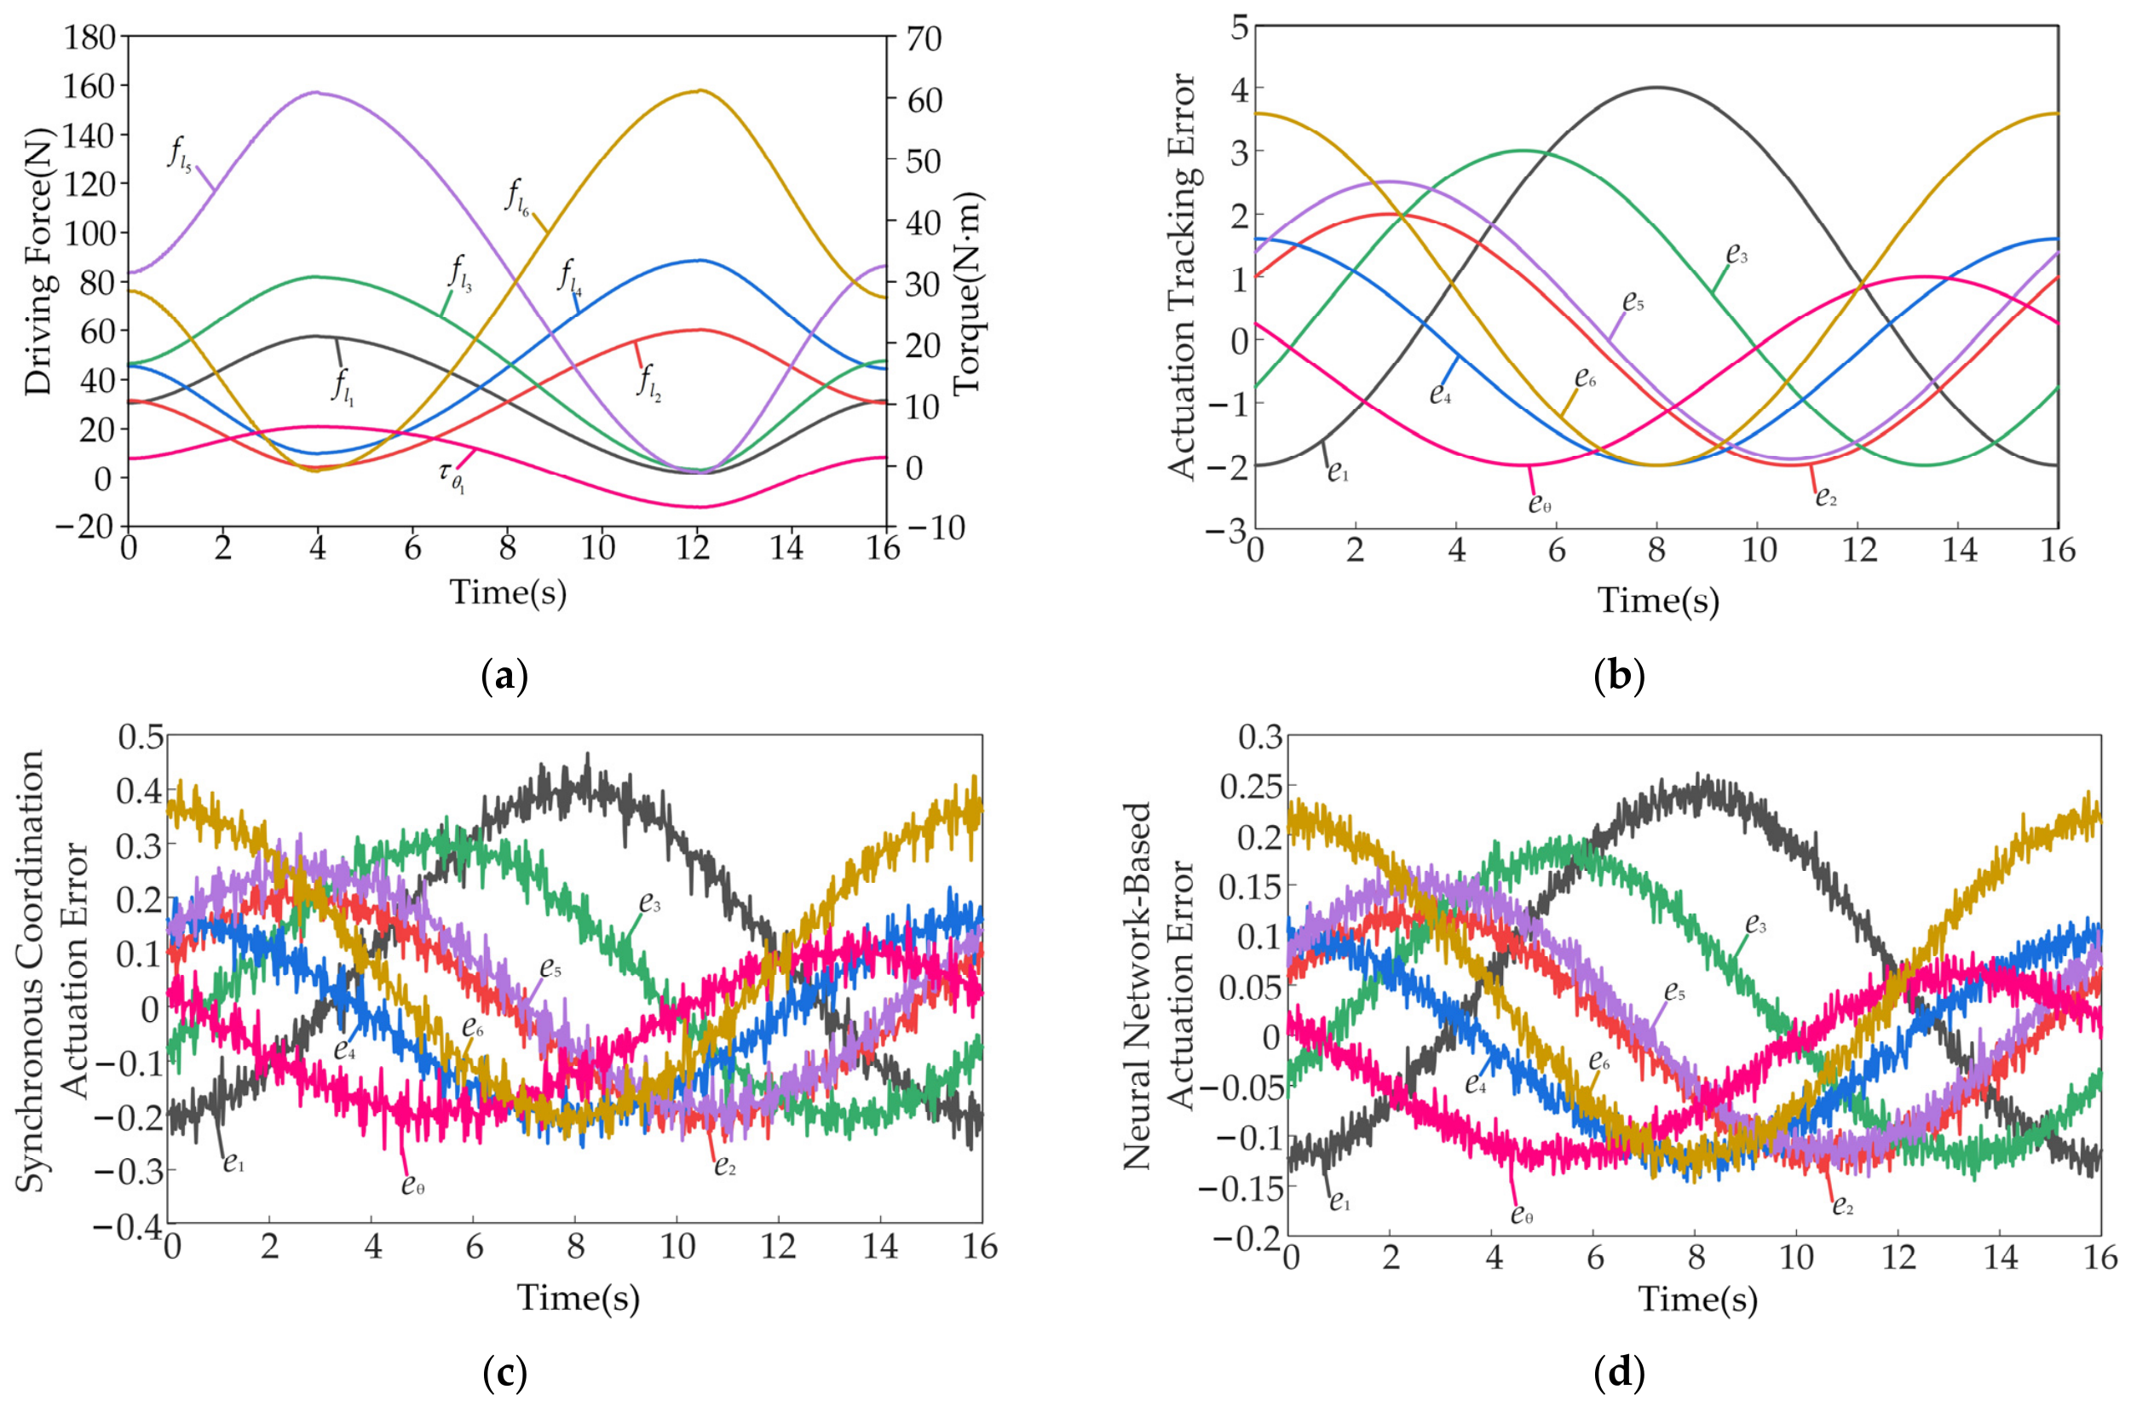
The trajectory for simulation and prototype experimentation is also the swing trajectory selected in the previous simulation section, and there are no singular configurations in the motion trajectory. Based on the inverse kinematics solution of the mechanism, the motion trajectory curves driven by #1~#5 are calculated, and based on the mechanism’s dynamic feedback, the driving force curves allocated to #1~#7 are calculated, as shown in Figure 14a. Three control strategies, namely force–position hybrid driving control, driving-synchronization control strategy, and neural network-based synchronous coordination control, are employed for simulation verification and prototype experiments of the robot. The errors between the actual driving outputs and the desired driving outputs of the robot are calculated during both simulation and experimental processes. The driving-force/torque error curves under the force–position hybrid driving control mode from simulation are shown in Figure 14b; the corresponding prototype experimental results are consistent with the simulation and are thus omitted here. The driving-force/torque error curves obtained from prototype experiments under the synchronous coordination control strategy and the neural network-based active internal force control strategy are presented in Figure 14c and Figure 14d, respectively, while their simulation results are omitted.
As shown in Figure 14, Figure 14a depicts the variation curves of the desired driving force/torque for each actuator, and the load of each branch varies periodically along the motion cycle. Figure 14b shows the actuation tracking error under conventional force–position hybrid control, where the peak error of each branch reaches 4.1 N·m and severe error fluctuation arises from multi-actuator coupling. After introducing the synchronous coordination control for actuators as shown in Figure 14c, the peak actuation error drops to 0.46 N·m, corresponding to a 90.8% reduction in error amplitude compared with the force–position hybrid control, which greatly alleviates tracking deviations originating from multi-chain coupling. With further optimization of synchronous coordination control via neural networks, as presented in Figure 14d, the peak actuation error is limited to 0.23 N·m. The error amplitude is further reduced by 50% relative to the synchronous coordination control, and the total error declines by 94.9% compared with the original force–position hybrid control. In addition, high-frequency random chattering on error curves is effectively suppressed. The stepwise optimization results demonstrate that synchronous coordination control preliminarily converges actuation errors, while the neural network further counteracts model uncertainties and coupling disturbances through adaptive compensation, substantially improving the load synchronous tracking precision of multiple driving branches.
It is necessary to discuss the limitations of the proposed control scheme in this study. First, the parameter tuning based on the BP neural network introduces additional computational workload. Although the network scale adopted in this paper is relatively small, the excessive computational complexity still imposes restrictions on the real-time implementation of the control algorithm on hardware platforms. This problem will become more prominent when the network scale is expanded to adapt to more complex robot prototypes. Second, the control performance is sensitive to variations in the robot’s mechanical structure, and large parametric deviations will degrade the force tracking accuracy. Although the force closed-loop feedback can effectively improve the anti-interference capability of the control system, it has limited robustness against severe external impact disturbances. These shortcomings will be further optimized and addressed in future research work.

7. Conclusions

This paper presents a novel three-platform parallel-coupled mobile robot. To address the issues of unbalanced internal force distribution and severe fluctuation in multi-branch driving forces in redundant-drive parallel mechanisms, kinematic analysis, dynamic modeling, and hybrid force–position control research were conducted. Specifically, dynamic modeling for both non-redundant and redundant drive configurations was completed. By comparing theoretical calculations with simulated force curves, the accuracy of the dynamic model was verified, laying a theoretical foundation for the subsequent design of control strategies.
Based on the idea of collaborative and integrated control, an active internal force regulation strategy and a multi-branch drive synchronous coordination control strategy are proposed. The experimental and simulation results show that, compared to the original force–position hybrid control, active internal force regulation can reduce the internal force error of the link to 11.6% of the initial error, and synchronous coordination control can reduce the drive error of each branch to 10.2% of the initial value, effectively suppressing the significant periodic oscillations caused by redundant coupling. Subsequently, a neural network adaptive algorithm is introduced, utilizing its adaptive compensation capability to offset model uncertainties and residual coupling disturbances. After optimization, the internal force error and drive error are reduced to 6.5% and 5.1% of the initial force–position hybrid control error, respectively. The high-frequency chattering synchronization phenomenon in the error curve is significantly improved, achieving high-precision tracking convergence of internal forces and multi-branch driving forces. The control strategy system proposed in this paper effectively solves the key problem of unreasonable internal force distribution in redundant parallel robots, improves the overall drive synchronization and motion smoothness of the robot, and provides a new approach for the design of force control schemes for robots operating in complex and rugged terrains.

Author Contributions

Conceptualization, W.H.; methodology, W.H., D.L. and R.L.; software, W.H. and D.L.; validation, W.H. and D.L.; formal analysis, W.H.; investigation, W.H.; resources, R.L.; writing—original draft preparation, W.H.; writing—review and editing, W.H.; visualization, W.H.; supervision, R.L.; funding acquisition, R.L. All authors have read and agreed to the published version of the manuscript.

Funding

This research was funded by the Key Research and Development Program of Shanxi Province of China, grant number 202202150401018; the Opening Foundation of Shanxi Key Laboratory of Advanced Manufacturing Technology, grant number XJZZ202105; and the Central Guidance for Local Science and Technology Development Fund Project, grant number YDZJSX2024D079.

Data Availability Statement

The raw data supporting the conclusions of this article will be made available by the authors on request.

Conflicts of Interest

The authors declare no conflicts of interest.

References

  1. Xu, K.; Wang, S.; Yue, B.; Wang, J.; Guo, F.; Chen, Z. Obstacle-Negotiation Performance on Challenging Terrain for a Parallel Leg-Wheeled Robot. J. Mech. Sci. Technol. 2020, 34, 377–386. [Google Scholar] [CrossRef] [Scilit]
  2. Ye, W.; Huo, T.; Gong, C.; Chen, Z. Design and Analysis of a Climbing Robot Consisting of a Parallel Mechanism and a Remote Center of Motion Mechanism. Robotica 2025, 43, 701–719. [Google Scholar] [CrossRef] [Scilit]
  3. Ju, Z.; Wei, K.; Xu, Y.; Zhao, Y. Design and analysis of 4SRRR legged wall-climbing robot. J. Adv. Manuf. Sci. Technol. 2023, 3, 2023005. [Google Scholar] [CrossRef] [Scilit]
  4. Shang, W.-W.; Cong, S.; Ge, Y. Adaptive Computed Torque Control for a Parallel Manipulator with Redundant Actuation. Robotica 2012, 30, 457–466. [Google Scholar] [CrossRef] [Scilit]
  5. Shao, J.; Chen, W.; Fu, X. Position, Singularity and Workspace Analysis of 3-PSR-O Spatial Parallel Manipulator. Chin. J. Mech. Eng. 2015, 28, 437–450. [Google Scholar] [CrossRef] [Scilit]
  6. Yıldız, B.; Çetin, L.; Gezgin, E. Control of mobile parallel manipulator. J. Intell. Syst. Appl. 2023, 6, 10–20. [Google Scholar] [CrossRef] [Scilit]
  7. Shang, W.; Cong, S. Robust Nonlinear Control of a Planar 2-DOF Parallel Manipulator with Redundant Actuation. Rob. Comput. Integr. Manuf. 2014, 30, 597–604. [Google Scholar] [CrossRef] [Scilit]
  8. Wen, H.; Cong, M.; Xu, W.; Zhang, Z.; Dai, M. Optimal Design of a Linkage-Cam Mechanism-Based Redundantly Actuated Parallel Manipulator. Front. Mech. Eng. 2021, 16, 451–467. [Google Scholar] [CrossRef] [Scilit]
  9. Shang, W.; Cong, S.; Ge, Y. Coordination Motion Control in the Task Space for Parallel Manipulators with Actuation Redundancy. IEEE Trans. Autom. Sci. Eng. 2013, 10, 665–673. [Google Scholar] [CrossRef] [Scilit]
  10. Feng, J.; Li, T.; Han, M.; Zheng, K.; Yang, D. Multi-Objective Trajectory Planning Method for a Redundantly Actuated Parallel Manipulator under Hybrid Force and Position Control. IEEE Access 2020, 8, 216707–216717. [Google Scholar] [CrossRef] [Scilit]
  11. Han, M.; Lian, W.; Liu, J.; Yang, D.; Li, T. Hybrid Force-Position Coordinated Control of a Parallel Mechanism with the Number of Redundant Actuators Equal to Its DOF. Proc. Inst. Mech. Eng. C J. Mech. Eng. Sci. 2024, 238, 11081–11096. [Google Scholar] [CrossRef] [Scilit]
  12. Wen, H.; Cong, M.; Wang, G.; Qin, W.; Xu, W.; Zhang, Z. Dynamics and Optimized Torque Distribution Based Force/Position Hybrid Control of a 4-DOF Redundantly Actuated Parallel Robot with Two Point-Contact Constraints. Int. J. Control Autom. Syst. 2019, 17, 1293–1303. [Google Scholar] [CrossRef] [Scilit]
  13. Wen, H.; Xu, W.; Cong, M. Kinematic Model and Analysis of an Actuation Redundant Parallel Robot with Higher Kinematic Pairs for Jaw Movement. IEEE Trans. Ind. Electron. 2015, 62, 1590–1598. [Google Scholar] [CrossRef] [Scilit]
  14. Wen, S.; Yu, H.; Zhang, B.; Zhao, Y.; Lam, H.K.; Qin, G.; Wang, H. Fuzzy Identification and Delay Compensation Based on the Force/Position Control Scheme of the 5-DOF Redundantly Actuated Parallel Robot. Int. J. Fuzzy Syst. 2017, 19, 124–140. [Google Scholar] [CrossRef] [Scilit]
  15. Wen, S.; Hu, X.; Zhang, B.; Sheng, M.; Lam, H.; Zhao, Y. Fractional-Order Internal Model Control Algorithm Based on the Force/Position Control Structure of Redundant Actuation Parallel Robot. Int. J. Adv. Robot. Syst. 2020, 17, 1729881419892143. [Google Scholar] [CrossRef] [Scilit]
  16. Wen, S.; Zhang, D.; Zhang, B.; Lam, H.K.; Wang, H.; Zhao, Y. Two-Degree-of-Freedom Internal Model Position Control and Fuzzy Fractional Force Control of Nonlinear Parallel Robot. Int. J. Syst. Sci. 2019, 50, 2261–2279. [Google Scholar] [CrossRef] [Scilit]
  17. Sakurai, S.; Katsura, S. Singularity-Free 3-Leg 6-DOF Spatial Parallel Robot with Actuation Redundancy. IEEJ J. Ind. Appl. 2024, 13, 127–134. [Google Scholar] [CrossRef] [Scilit]
  18. Shikata, K.; Katsura, S. Modal Space Control of Bilateral System with Elasticity for Stable Contact Motion. IEEJ J. Ind. Appl. 2023, 12, 131–144. [Google Scholar] [CrossRef] [Scilit]
  19. Sakurai, S.; Katsura, S. Force Control in Internal/External Modes for Redundantly Actuated Systems Using Modal Space Observer. Adv. Robot. 2025, 39, 532–549. [Google Scholar] [CrossRef] [Scilit]
  20. Sakurai, S.; Katsura, S. Position/Force Hybrid Control of Redundantly Actuated Cable-Driven Parallel Robot Based on Modal System Design. IEEE/ASME Trans. Mechatron. 2025, 30, 7537–7546. [Google Scholar] [CrossRef] [Scilit]
  21. Xi, F.; Moosavian, A.; Campos, G.H.; Choudhuri, U.; Sun, C.Z.; Buchkazanian, R. Analysis and Control of an Actuation-Redundant Parallel Mechanism Requiring Synchronization. J. Mech. Robot. 2020, 12, 044501. [Google Scholar] [CrossRef] [Scilit]
  22. Zhang, H.-Q.; Fang, H.-R.; Jiang, B.-S.; Wang, S.-G. Dynamic Performance Evaluation of a Redundantly Actuated and Over-Constrained Parallel Manipulator. Int. J. Autom. Comput. 2019, 16, 274–285. [Google Scholar] [CrossRef] [Scilit]
  23. Zhang, H.; Fang, H.; Zou, Q. Non-Singular Terminal Sliding Mode Control for Redundantly Actuated Parallel Mechanism. Int. J. Adv. Robot. Syst. 2020, 17, 172988142091954. [Google Scholar] [CrossRef] [Scilit]
  24. Zhang, H.; Fang, H.; Zhang, D.; Zou, Q.; Luo, X. Trajectory Tracking Control Study of a New Parallel Mechanism with Redundant Actuation. Int. J. Aerosp. Eng. 2020, 2020, 7178103. [Google Scholar] [CrossRef] [Scilit]
  25. Zhang, H.; Fang, H.; Zou, Q.; Song, M.; Zhu, T. Force-Position Hybrid Control of a Novel Parallel Manipulator with Redundant Actuation. In 2019 WRC Symposium on Advanced Robotics and Automation (WRC SARA); IEEE: Piscataway, NJ, USA, 2019; pp. 128–133. [Google Scholar]
  26. Huang, L.; Xu, W.L.; Torrance, J.; Bronlund, J.E. Modeling and Impedance Control of a Chewing Robot with a 6RSS Parallel Mechanism. In Proceedings of the International Conference on Intelligent Robotics and Applications; Springer: Berlin/Heidelberg, Germany, 2009; pp. 733–743. [Google Scholar]
  27. Huang, L.; Xu, W.L.; Torrance, J.; Bronlund, J.E. Design of a Position and Force Control Scheme for 6rss Parallel Robots and Its Application in Chewing Robots. Int. J. Humanoid Robot. 2010, 7, 477–489. [Google Scholar] [CrossRef] [Scilit]
  28. Yan, J.; Liu, M.; Jin, L. Cerebellum-Inspired Model Predictive Control for Redundant Manipulators with Unknown Structure Information. IEEE Trans. Cogn. Dev. Syst. 2024, 16, 1198–1210. [Google Scholar] [CrossRef] [Scilit]
  29. Yan, J.; Jin, L.; Hu, B. Data-Driven Model Predictive Control for Redundant Manipulators with Unknown Model. IEEE Trans. Cybern. 2024, 54, 5901–5911. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  30. Yan, J.; Liu, M. Neural Dynamics-Based Model Predictive Control for Mobile Redundant Manipulators with Improved Obstacle Avoidance. IEEE Trans. Ind. Electron. 2024, 72, 2769–2778. [Google Scholar] [CrossRef] [Scilit]
  31. Xing, H.; Torabi, A.; Ding, L.; Tavakoli, M. Enhancement of Force Exertion Capability of a Mobile Manipulator by Kinematic Reconfiguration. IEEE Robot. Autom. Lett. 2020, 5, 5842–5849. [Google Scholar] [CrossRef] [Scilit]
  32. Xing, H.; Torabi, A.; Ding, L.; Gao, H.; Deng, Z.; Mushahwar, V.K.; Tavakoli, M. An Admittance-Controlled Wheeled Mobile Manipulator for Mobility Assistance: Human-Robot Interaction Estimation and Redundancy Resolution for Enhanced Force Exertion Ability. Mechatronics 2021, 74, 102497. [Google Scholar] [CrossRef] [Scilit]
  33. Xing, H.; Torabi, A.; Ding, L. Enhancing Kinematic Accuracy of Redundant Wheeled Mobile Manipulators via Adaptive Motion Planning. Mechatronics 2021, 79, 102639. [Google Scholar] [CrossRef] [Scilit]
  34. Ding, L.; Xing, H.; Gao, H.; Torabi, A.; Li, W.; Tavakoli, M. VDC-Based Admittance Control of Multi-DOF Manipulators Considering Joint Flexibility via Hierarchical Control Framework. Control Eng. Pract. 2022, 124, 105186. [Google Scholar] [CrossRef] [Scilit]
  35. Xing, H.; Gong, Z.; Ding, L.; Torabi, A.; Chen, J.; Gao, H.; Tavakoli, M. An Adaptive Multi-Objective Motion Distribution Framework for Wheeled Mobile Manipulators via Null-Space Exploration. Mechatronics 2023, 90, 102949. [Google Scholar] [CrossRef] [Scilit]
  36. Xing, H.; Ding, L.; Gao, H.; Li, W.; Tavakoli, M. Dual-User Haptic Teleoperation of Complementary Motions of a Redundant Wheeled Mobile Manipulator Considering Task Priority. IEEE Trans. Syst. Man Cybern. Syst. 2022, 52, 6283–6295. [Google Scholar] [CrossRef] [Scilit]
  37. Ren, C.; Zhang, H.; Li, H.; Li, Q.; Ye, W. Dual-Space Dynamics Adaptive Synchronization Control for Redundantly Actuated Parallel Robots. J. Mech. Robot. 2026, 18, 061009. [Google Scholar] [CrossRef] [Scilit]
  38. Xu, L.; Chen, G.; Ye, W.; Li, Q. Design, Analysis and Optimization of Hex4, a New 2R1T Overconstrained Parallel Manipulator with Actuation Redundancy. Robotica 2019, 37, 358–377. [Google Scholar] [CrossRef] [Scilit]
  39. Zhang, H.; Ye, W.; Li, Q. Robust Decoupling Control of a Parallel Kinematic Machine Using the Time-Delay Estimation Technique. Sci. China Technol. Sci. 2023, 66, 1916–1927. [Google Scholar] [CrossRef] [Scilit]
  40. Cheng, H.; Yiu, Y.-K.; Li, Z. Dynamics and Control of Redundantly Actuated Parallel Manipulators. IEEE/ASME Trans. Mechatron. 2003, 8, 483–491. [Google Scholar] [CrossRef] [Scilit]
  41. Mueller, A. Redundant Actuation of Parallel Manipulators; INTECH Open Access Publisher: London, UK, 2008; pp. 1–22. [Google Scholar]
  42. Majji, M.; Junkins, J. Robust Control of Redundantly Actuated Dynamical Systems. In Proceedings of the AIAA Guidance, Navigation, and Control Conference and Exhibit, Keystone, CO, USA, 21–24 August 2006; AIAA Paper 2006–6235; AIAA: Reston, VA, USA, 2006. [Google Scholar][Green Version]
  43. Jia, G.; Huang, H.; Wang, S.; Li, B. Type synthesis of plane-symmetric deployable grasping parallel mechanisms using constraint force parallelogram law. Mech. Mach. Theory 2021, 161, 104330. [Google Scholar] [CrossRef] [Scilit]
  44. Ding, H.; Yang, X.; Zheng, N.; Li, M.; Lai, Y.; Wu, H. Tri-Co Robot: A Chinese Robotic Research Initiative for Enhanced Robot Interaction Capabilities. Natl. Sci. Rev. 2018, 5, 799–801. [Google Scholar] [CrossRef] [Scilit]
  45. Xu, W.; Li, X.; Xu, W.; Gong, L.; Huang, Y.; Zhao, Z.; Zhao, L.; Chen, B.; Yang, H.; Cao, L.; et al. Human-Robot Interaction Oriented Human-in-the-Loop Real-Time Motion Imitation on a Humanoid Tri-Co Robot. In Proceedings of the 2018 3rd International Conference on Advanced Robotics and Mechatronics (ICARM), Singapore, 18–20 July 2018; pp. 781–786. [Google Scholar]
Figure 1. Three-platform parallel robot: (a) 3D model; (b) schematic diagram.
Machines 14 01080 g001
Figure 2. Force model of the non-redundantly actuated robot.
Machines 14 01080 g002
Figure 3. Force model of the redundantly actuated robot.
Machines 14 01080 g003
Figure 4. Distribution of driving forces and moments: (a) Distribution obtained by model simulation; (b) distribution obtained by theoretical calculation.
Machines 14 01080 g004
Figure 5. Active internal force control strategy.
Machines 14 01080 g005
Figure 6. Active internal force regulation strategy for robots.
Machines 14 01080 g006
Figure 7. Synchronous coordination control strategy.
Machines 14 01080 g007
Figure 8. Robot synchronous coordination control strategy.
Machines 14 01080 g008
Figure 9. Neural network-based active internal force regulation.
Machines 14 01080 g009
Figure 10. Neural network-based PID control unit.
Machines 14 01080 g010
Figure 11. Neural network-based synchronous coordination control unit.
Machines 14 01080 g011
Figure 12. Photograph of the physical prototype.
Machines 14 01080 g012
Figure 13. Desired connecting rod internal force and tracking results: (a) Simulated desired internal force; (b) simulated internal force error under conventional force–position hybrid control; (c) experimental internal force error under active internal force control; (d) experimental internal force error under neural network-based active internal force control.
Machines 14 01080 g013
Figure 14. Desired driving force/torque and tracking results: (a) Simulated desired driving force/torque; (b) simulated actuator tracking error under conventional force–position hybrid control; (c) experimental actuator tracking error under synchronous coordinated control; (d) experimental actuator tracking error under neural network synchronous coordinated control.
Machines 14 01080 g014
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content.