


Abstract
The aim of this work is to present new oscillation results for a class of second-order delay differential equations with damping term. The new criterion of oscillation depends on improving the asymptotic properties of the positive solutions of the studied equation by using an iterative technique. Our results extend some of the results recently published in the literature.
1. Introdiction
This article is concerned with studying the oscillatory behavior of the second-order delay differential equation
where r, q, , r is positive, q is nonnegative, , and
By a solution of (1), we mean a function which has the property is differentiable and satisfies (1) on . We consider only those solutions of (1) which satisfy for all Oscillatory term is related to a solution if arbitrarily large zeros on exist. Equation (1) is said to be oscillatory if all its solutions are oscillatory.
Differential and difference equations have been used, since long time ago, to describe natural phenomena and have many applications in different sciences. Therefore, it is natural to notice an increasing interest in studying the qualitative properties of these equations, for example [1,2,3]. Oscillation theory is a branch of the qualitative theory of functional differential equations, which is concerned with the study of the oscillatory and non-oscillatory behavior of solutions to differential equations. The growing interest and development in the oscillation theory of delay differential equations can be seen through the works [4,5,6,7].
For second-order with damping term, Saker et al. [8] established Kamenev-type and Philos-type theorems for oscillation of equation with damping term
The results in [8] extended and improved results in [9,10,11]. Graef et al. [12] studied the oscillatory behavior of equations with damping term
under the condition
The objective of this paper is to establish new oscillation criteria for (1) in the non-canonical case. We offer a one-condition criterion which guarantees the oscillation of all solutions of the studied equation. The new criterion is also characterized by an iterative nature, meaning that it can be applied several times even if it fails in the beginning. Finally, we present an example that demonstrates the importance and applicability of the results.
2. Main Results I: Delay Equation
In this section, we assume that . For the sake of brevity, we define
and
We provide the lemmas that help us achieve the main results.
Lemma 1.
Assume that ϕ is an eventually positive solution of (1). Then, , and there exists such that one of the following cases hold:
- for
Proof.
Suppose that there exists such that and are positive functions. As a direct conclusion from (1) and the definition of we get
which means that is a nonincreasing function and has one sign eventually. This means that is of one sign eventually, since is positive. This ends the proof. □
Lemma 2.
Proof.
Assume on the contrary that is an eventually positive solution of (1) satisfying case for . As a direct conclusion from (1) and the definition of we get
Since is positive and increasing, there exists k which is a positive constant such that and eventually. Therefore, we obtain
and so
which is a contradiction, and hence satisfies .
: Consequently, . We claim that . If not, then there exists a such that for . Thus, from (5), we have
Then,
By integrating once again from to provides
which is a contradiction, and thus .
: Using that is non-increasing, we have
: Using the product rule to differentiate and using in the numerator it follows that is non-increasing.
Since is positive and decreasing, We claim that . If not, then eventually. Now, we define
Then, from , and
Using (6) and the fact that , we get
Integrating the last inequality from to t, we obtain
which is a contradiction and we conclude that
: We can rewrite (4) as
The last inequality implies that
This ends the proof. □
Lemma 3.
where
Proof.
Assume that is an eventually positive solution of (1). From Lemma 2, we have satisfies and hold. Integrating (4) from to t and using the fact that is decreasing, we get
which in view of (3) implies
and
Since as , we obtain
and then is decreasing.
Next, proceeding as in the proof of and in Lemma 2, we can prove and . □
Theorem 1.
Proof.
Assume the contrary that is an eventually positive solution of (1). From Lemmas 2 and 3, we have and hold. Thus, by using induction, we can prove that
Hence, we obtain
and
This implies
Then , which is a contradiction. Therefore, the proof is complete. □
Theorem 2.
Proof.
Assume the contrary that is an eventually positive solution of (1). We define the function
It follows from Lemma 2 that and; moreover
Since is decreasing, then and so
Example 1.
Example 2.
Consider the second order delay differential equation
where and . We note that , and . So, condition (14) reduces to
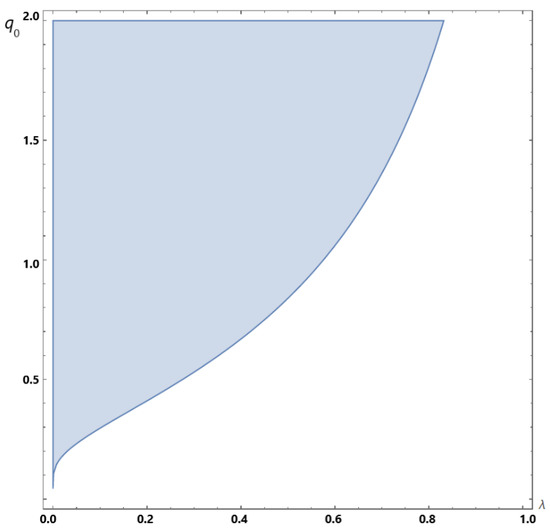
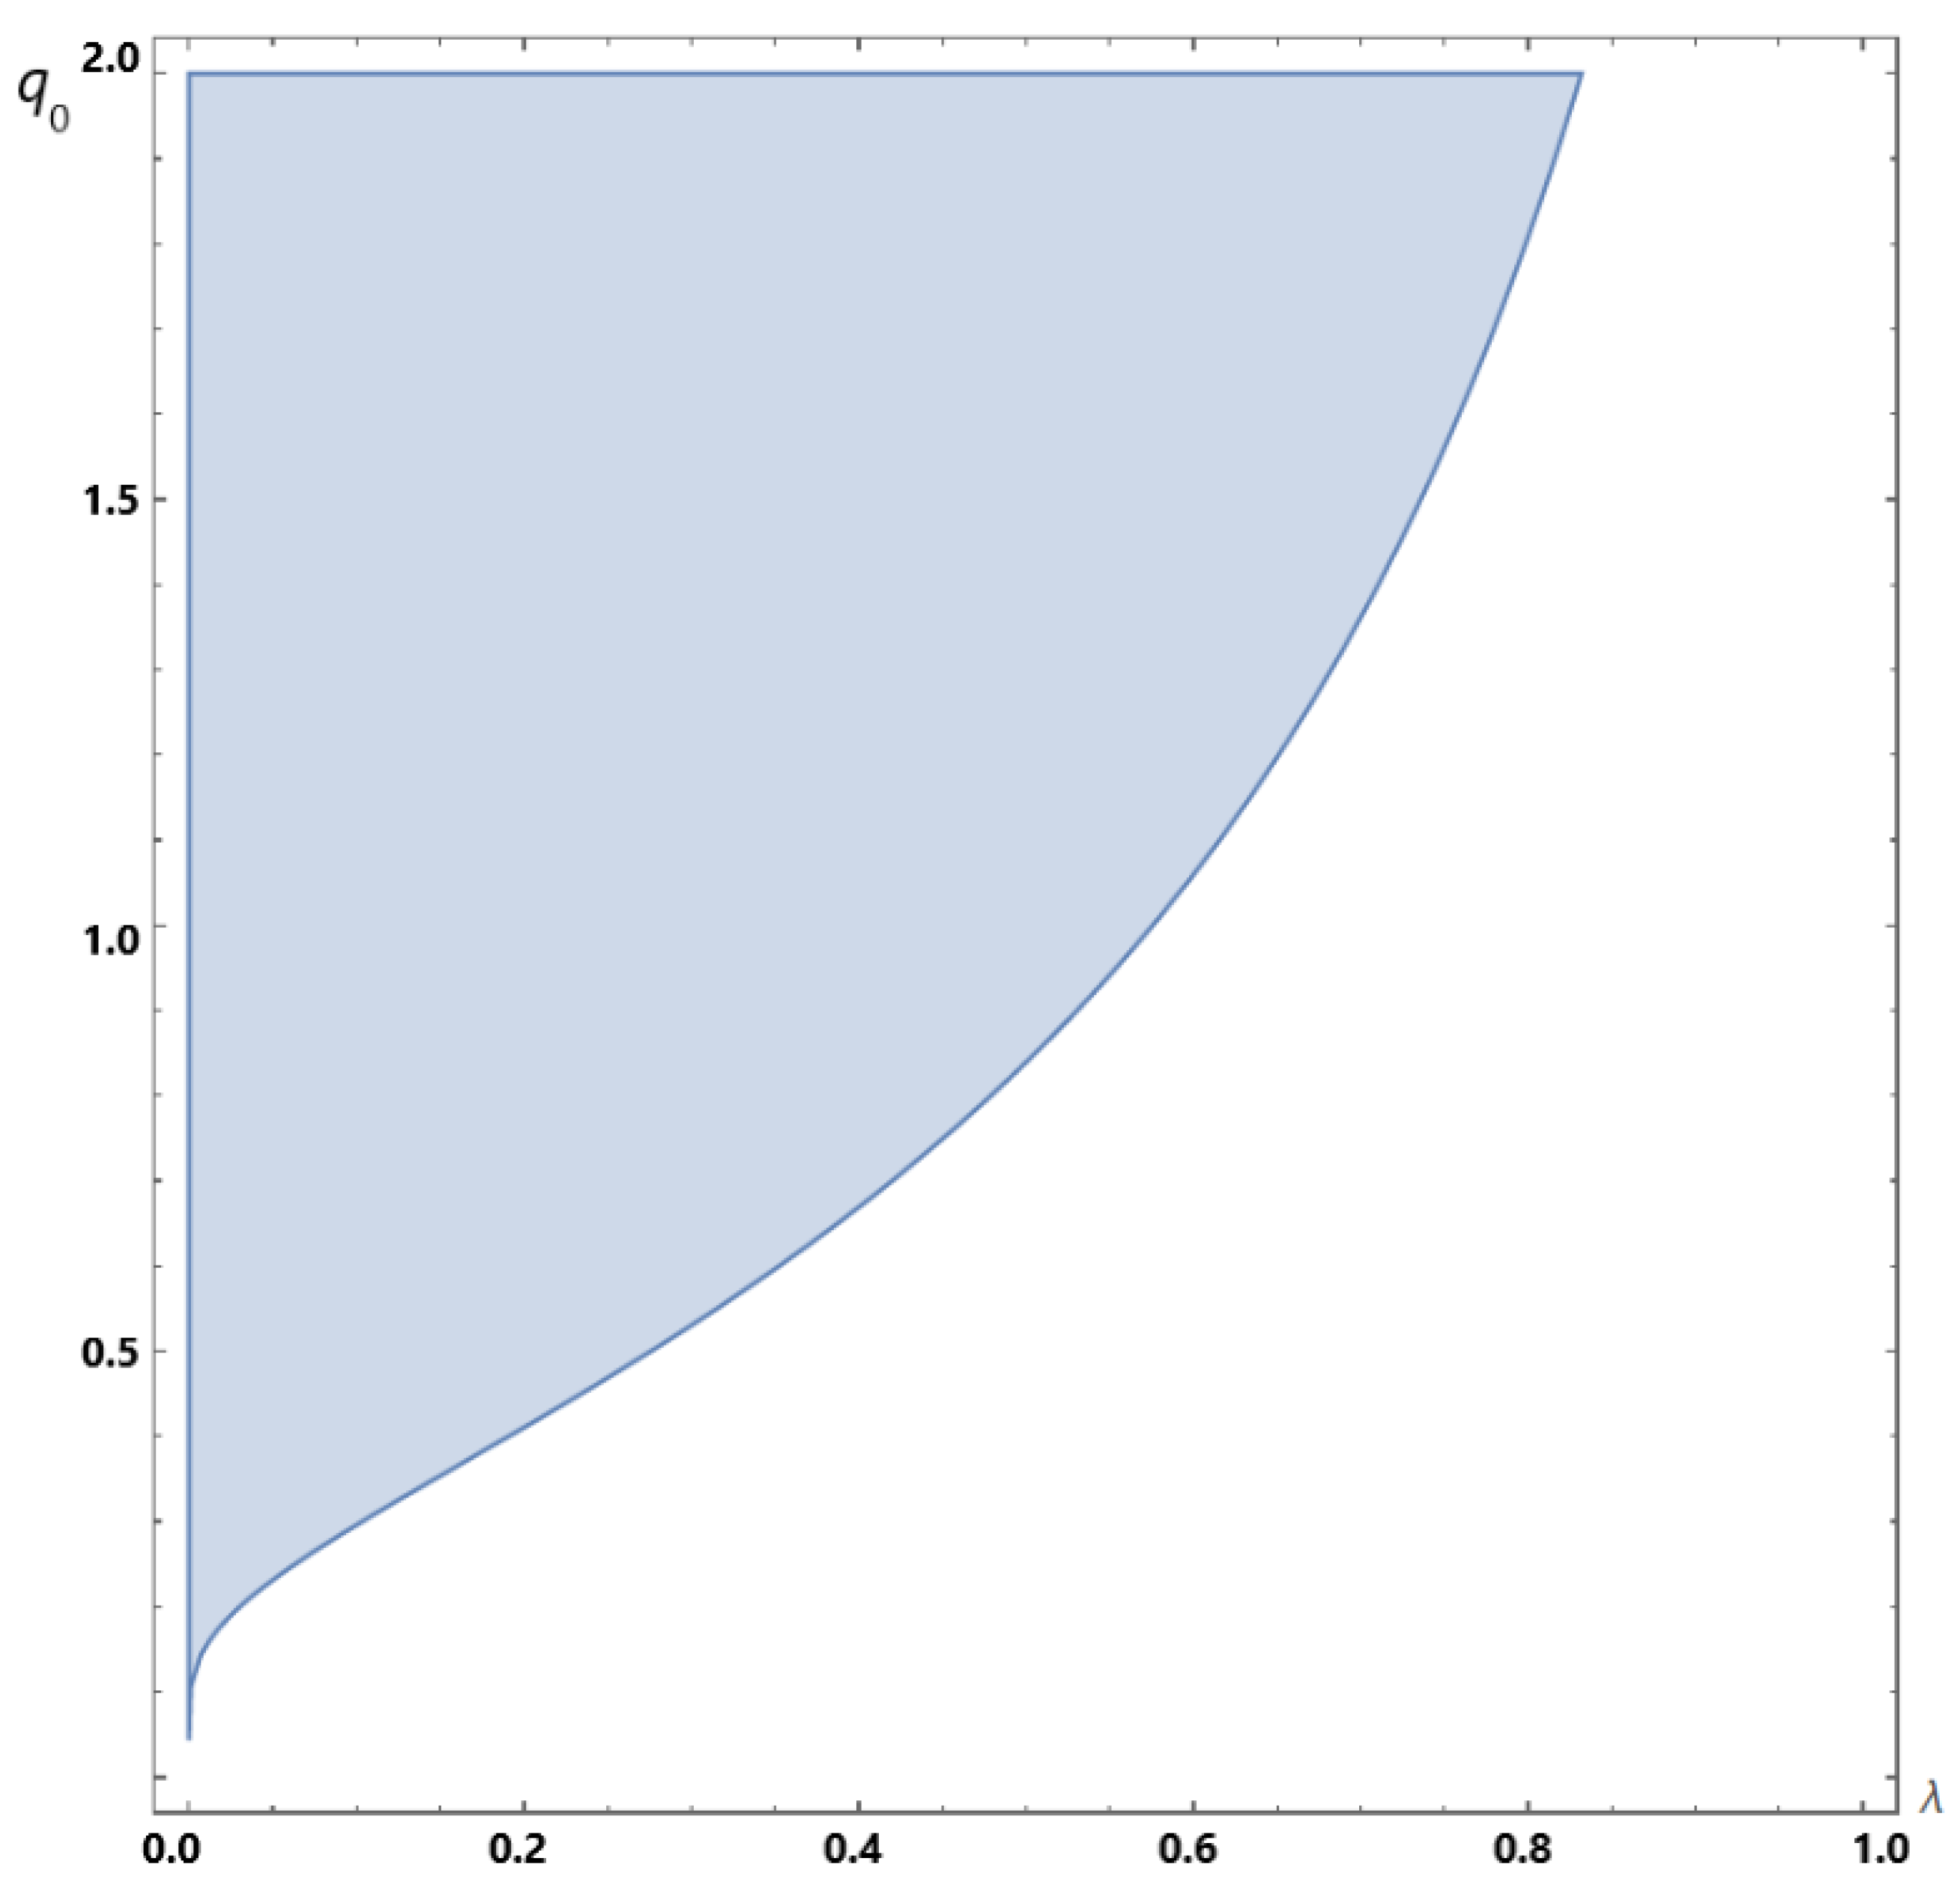
with iterative defined by (12). If then we get and condition (20) reduces to
Figure 1.
Regions for which Condition (21) are satisfied.
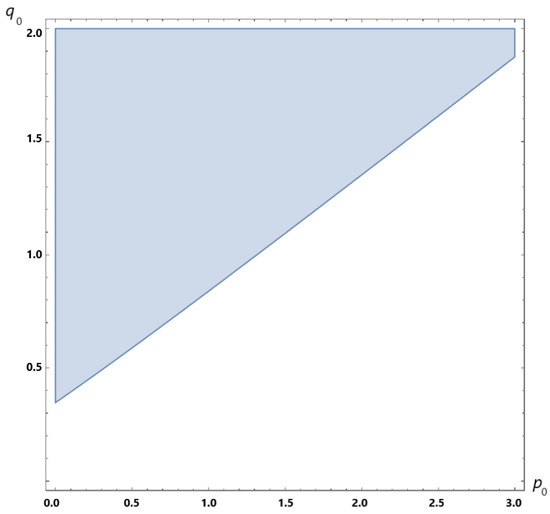
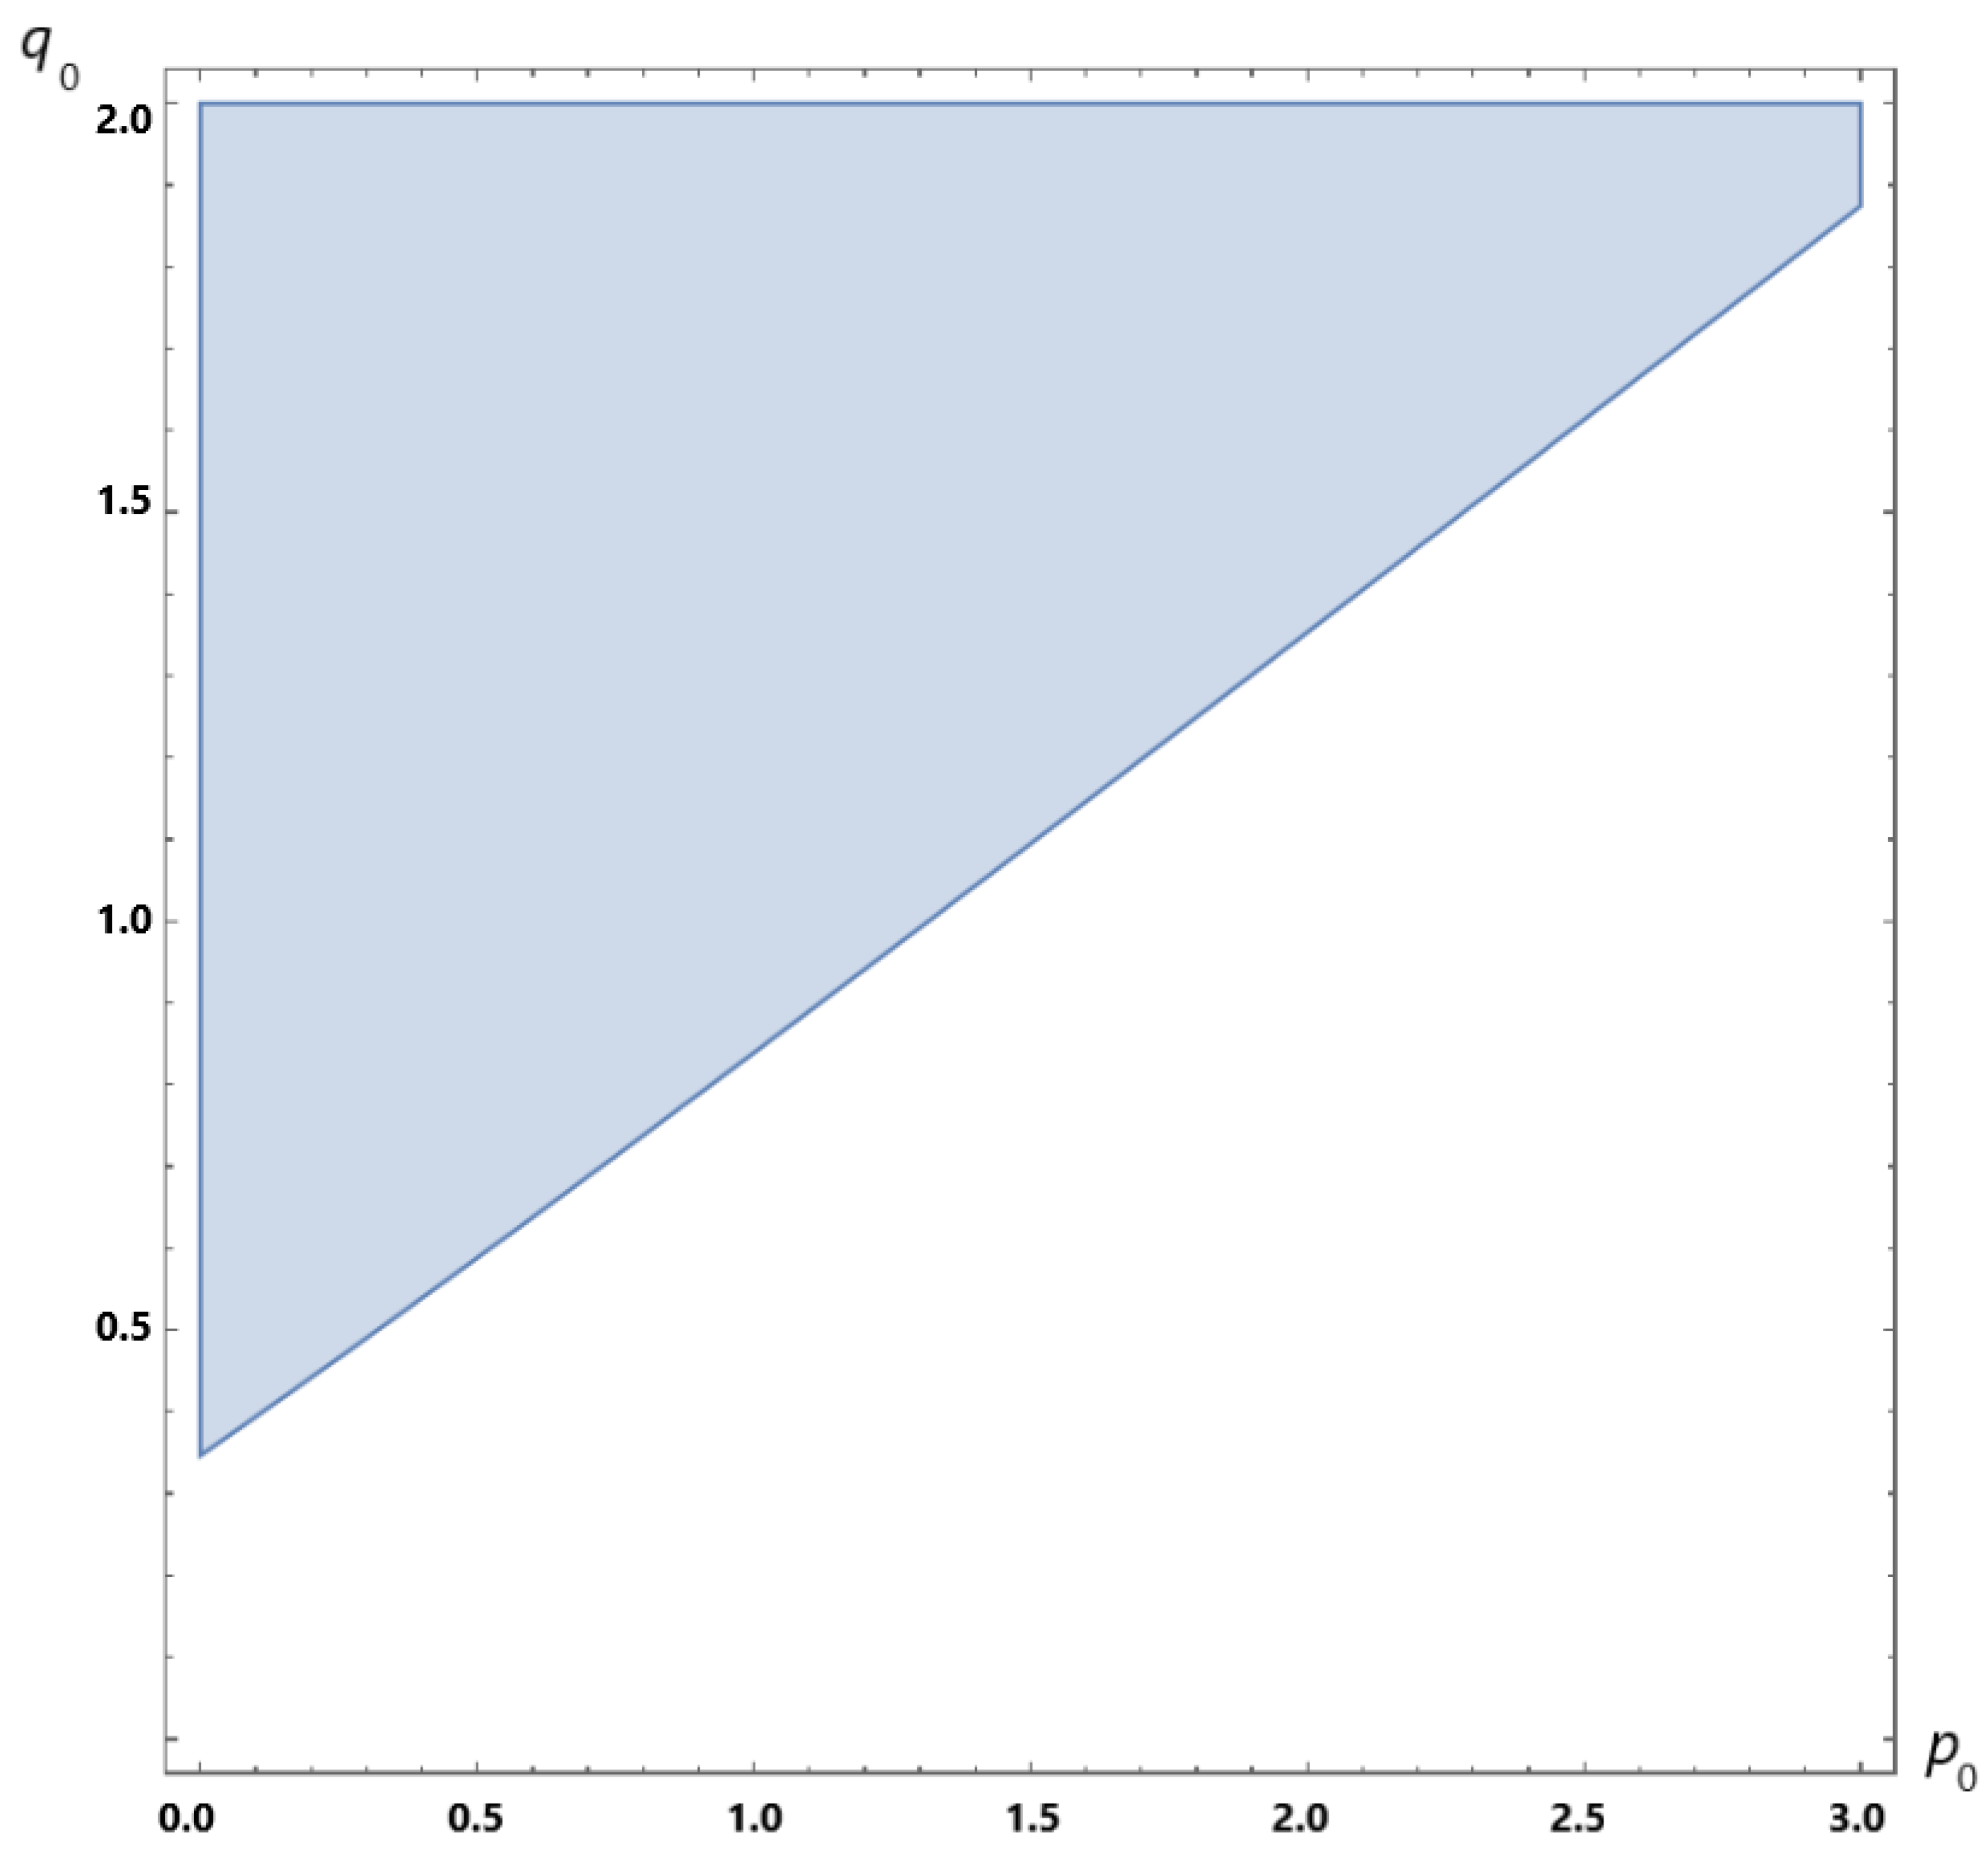
Figure 2.
Regions for which Conditions (22) are satisfied.
Remark 1.
If then then our results are reduced to the results of Baculikova in [14]. However, Baculikova’s results require the extra condition
which we do not use here, instead we use (3).
3. Main Results II: Advanced Equation
The above method can be modified to serve also advanced differential equations, when . We slightly modify the key constant to as follows.
Lemma 4.
Assume that there exists a such that
holds and where ω is constant. If ϕ is a positive solution of (1) then
Proof.
Assume that is an eventually positive solution of (1). From Lemma 2, we have satisfies and
Integrating (4) from to t we get
from the inequality (24) we have
where we have used that as . therefor,
To prove parts and we proceed exactly as in the proof of Lemma 2. The proof is complete. □
Theorem 3.
Theorem 4.
Author Contributions
The authors contributed equally to this article. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Acknowledgments
This work has been supported by the Polish National Science Centre, Poland under the grant OPUS 18 No. 2019/35/B/ST8/00980. All authors have read and agreed to the published version of the manuscript.
Conflicts of Interest
There are no competing interests.
References
- Agarwal, R.P.; Grace, S.R.; O’Regan, D. Oscillation Theory for Difference and Functional Differential Equations; Marcel Dekker: New York, NY, USA; Kluwer Academic: Dordrecht, The Netherlands, 2000. [Google Scholar]
- Hale, J.K. Theory of Functional Differential Equations; Springer: NewYork, NY, USA, 1977. [Google Scholar]
- Kocic, V.L.; Ladas, G. Global Behavior of Nonlinear Difference Equations of Higher Order with Applications; Kluwer Academic Publishers: Dordrecht, The Netherlands, 1993. [Google Scholar]
- Dzurina, J.; Grace, S.R.; Jadlovska, I.; Li, T. Oscillation criteria for second-order Emden—Fowler delay differential equations with a sublinear neutral term. Math. Nachr. 2020, 293, 910–922. [Google Scholar] [CrossRef] [Scilit]
- Moaaz, O.; Anis, M.; Baleanu, D.; Muhib, A. More effective criteria for oscillation of second-order differential equations with neutral arguments. Mathematics 2020, 8, 986. [Google Scholar]
- Moaaz, O.; Baleanu, D.; Muhib, A. New aspects for non-existence of kneser solutions of neutral differential equations with odd-order. Mathematics 2020, 8, 494. [Google Scholar] [CrossRef] [Scilit]
- Moaaz, O.; Furuichi, S.; Muhib, A. New comparison theorems for the nth order neutral differential equations with delay inequalities. Mathematics 2020, 8, 454. [Google Scholar] [CrossRef] [Scilit]
- Saker, S.H.; Pang, P.Y.; Agarwal, R.P. Oscillation theorem for second-order nonlinear functional differential equation with damping. Dyn. Syst. Appl. 2003, 12, 307–322. [Google Scholar]
- Grace, S.R. Oscillation theorems for second order nonlinear differential equations with damping. Math. Nachr. 1989, 141, 117–127. [Google Scholar] [CrossRef] [Scilit]
- Grace, S.R. On the oscillatory and asymptotic behavior of damping functional differential equations. Math. Jpn. 1991, 36, 220–237. [Google Scholar]
- Grace, S.R. Oscillation of nonlinear differential equations of second order. Publ. Math. 1992, 40, 143–153. [Google Scholar] [CrossRef] [Scilit]
- Graef, J.R.; Özdemir, O.; Kaymaz, A.; Tunc, E. Oscillation of damped second-order linear mixed neutral differential equations. Monatshefte Math. 2021, 194, 85–104. [Google Scholar] [CrossRef] [Scilit]
- Ladde, G.S.; Lakshmikantham, V.; Zhang, B.G. Oscillation Theory of Differential Equations with Deviating Arguments; Marcel Dekker: New York, NY, USA, 1987. [Google Scholar]
- Baculikova, B. Oscillatory behavior of the second order noncanonical differential equa tions. Electron. J. Qual. Theory Differ. Equ. 2019. [Google Scholar] [CrossRef] [Scilit]
Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2021 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).