


Abstract
Many jurisdictions globally have adopted a zero road trauma target by 2050 and an interim target of a 50% reduction by 2030. The objective of this study was to investigate what the road system will need to look like in order to achieve these respective targets. Utilising human tolerance to injury as the key design factor, this study defined the combination of vehicle, infrastructure, and travel speed requirements to manage crash energy in order to: 1. prevent all fatalities and serious injuries by 2050 in an Ultimate Safe System scenario; and 2. significantly reduce fatalities and severe injuries by 2030 in an Interim Safe System scenario. Victoria, Australia and its Movement and Place (M&P) framework was employed as a case study. With the vehicle and infrastructure countermeasures currently available coupled with appropriate travel speeds it is possible to construct an Ultimate Safe System that can manage crash forces to achieve zero trauma and an Interim Safe System that can significantly reduce the most severe injuries in Victoria. This study has demonstrated a potential pathway from the current situation to 2030 and then 2050 that can achieve safety targets while meeting the core objectives of the transport system.
1. Introduction and Aims
In 2020, the United Nations (UN) General Assembly declared the timeframe between 2021–2030 the second Decade of Action for road safety and set the ambitious target for countries to achieve at least a 50% reduction in road fatalities and injuries by 2030 [1]. Governments and countries globally were encouraged to develop appropriate road safety strategies and actions to achieve this ambitious target. Governments have taken this one step further, and have committed to not just an interim target of a 50% reduction by 2030 but to zero fatalities and serious injuries by a set year. For example, the United States, Victoria in Australia, New Zealand, and the European Commission have all set a zero or near zero target by 2050.
It is commendable that jurisdictions are aiming for zero; however, current strategy development processes appear to be insufficient to support this ambition. Road safety strategies are often planned in 3–5 or 10 year cycles [2] attached to a set of interim casualty reductions targets without a concurrent long term plan on how to build a safe road system that can help ultimately achieve zero road trauma. While the ultimate goal of any road safety strategy is to reduce road trauma, in determining the ability of a road safety strategy in setting out a long-term pathway to zero, casualty reduction targets alone should not be the only measure of success. Rather than focus solely on short-term trauma targets, it is important to set out parameters of what a safe road transport system should look like and track its progress in obtaining that. However, many strategies focus on short to medium term goals without considering what is required to achieve this long-term zero objective.
It is clear that to achieve an interim 50% target and ultimately a zero target requires the development of a systematic and sustainable pathway of transformation from the current road transport system to a future safe road system that can ultimately prevent all serious road trauma. A sustainable pathway would involve gradually removing the underlying risk in the transport system by improving infrastructure and vehicles, along with appropriate speed limiting setting and management, to a stage where crash severity does not exceed human physical tolerance and without a strong dependency on road users always behaving appropriately due to the propensity for people to make mistakes as well as wilfully transgress. Job, Truong and Sakashita [3] defined ‘a system in which people cannot be killed or seriously injured regardless of their behaviour or the behaviour of other road users’ as an Ultimate Safe System.
1.1. Ultimate Safe System—The Desirable Future State
In visualizing how to design a safe road transport system that is true to the moral imperative of achieving zero deaths and serious injuries, an Ultimate Safe System should, according to Job, Truong and Sakashita [3], be one in which:
- Road users are never exposed to forces which are not survivable or can create long-term debilitations even when they or others make mistakes, including deliberate risk-taking;
- the network incorporates road and vehicle features that are maintained, reliable, and effective, and can prevent deaths and serious injuries without being reliant on road user behaviour and compliance with laws;
- the network includes setting and achieving compliance with the speed limits through vehicle engineering without relying on drivers to choose to comply with limits.
There is no single initiative or road safety intervention that alone can accomplish the elimination of road trauma. Instead, research increasingly indicate a systemic approach to trauma reduction is required [4]; this thinking has been utilized in other industries to recognize that each part of the system has an important role to play and that even small changes in one area can make a significant difference to the effectiveness of the overall system [5]. In recent times, the Safe System approach is frequently used to guide the effective development of strategies to reduce road trauma [6,7]. While there may be issues with the interpretation of how the Safe System approach should be applied [3], it clearly highlights the need to take a systems perspective rather than a siloed approach when addressing road safety. Especially with the expanding development and availability of technologies such as electronic stability control [8,9], autonomous emergency braking [10], and lane keeping systems [11] that can help increase safety and decrease reliance on road user behaviour, there is a need to better understand the interactions and synergies between all parts that make up the transport system in order to effectively design a safe road system. In the future, as systems and technologies develop even further and interconnectedness becomes more prevalent, additional consideration will need to be given to supporting elements, such as the security of the system [12] and how to utilize these developments to enhance safety on the roads [13].
Fortunately, there is growing evidence as to what a safe road system needs to entail and the minimum requirements for roads, vehicles, and road users and how these components, together with speed, should interact to create safe traffic use [14]. Therefore, to achieve zero fatalities and serious injuries, it is necessary to define the joint requirements for vehicles, roads, and speed to achieve a future Ultimate Safe System. In an Ultimate Safe System, the system should be able to protect a road user from serious harm despite any unintentional mistakes or deliberate risk taking (e.g., drug driving). When a mistake or transgression occurs, an Ultimate Safe System should be able to guarantee safety through vehicle and infrastructure specifications in combination with speed setting and management to ensure the impact stays within acceptable injury tolerance levels. It is anticipated that these key elements will be able to help enforce most of the road user behaviors required, and thus there will be minimal reliance on road users to behave appropriately, due to their propensity to make mistakes. Nonetheless, road user compliance programs (e.g., police enforcement) will be very much required in the interim phase in the lead up to having a fully Ultimate Safe System.
Using a back-casting approach, one strategy might be to begin with defining an Ultimate Safe System before working backwards to define an appropriate Interim Safe System that can help meet any interim road safety target that has been set, and then to the current road safety situation. Back-casting works to determine the feasibility of that desirable future state, what policy measures would be required to reach that point, and highlight what the discrepancies are by testing alternatives based on existing risks [15]; this shifts the focus from prediction and likelihood to feasibility and choice [16].
1.2. Human Tolerance to Crash Forces
It is recognised that health losses are not randomly related to crashes and instead correspond to the amount of external forces to which one is exposed [17]. Therefore, to reduce road trauma it will be necessary to either prevent impact or mitigate the level of forces generated by an impact to a level that is within human tolerance and does not result in death or long-term health losses.
The human body has a predefined level of tolerance to external forces, varying with age, and becomes susceptible to injuries once the tolerance has been exceeded; this is known as the human tolerance to crash forces. To effectively reduce road trauma, the dissipation of kinetic energy within the road system needs to be controlled. Movement and access, i.e., travel speed, in this road system should be a function of the ability of roads and vehicles to effectively moderate crash forces to within human tolerance. Speed management thereby becomes the tool to regulate crash forces within the system by adapting the speed limit to the boundaries given by roads and vehicles.
The early Vision Zero system design principles were based on injury risk curves, i.e., the mathematical relationship between crash force and injury risk, where travel speed was used as a proxy for crash force [18]. Informed by risk curves on the likelihood of death and injuries by crash forces, the maximum possible travel speed for different crash types based on an inherently safe road system that will not result in deaths and serious injuries were refined to be:
- Locations with possible conflicts between pedestrians and cars = 30 km/h
- Intersections with possible side impacts between cars = 50 km/h
- Roads with possible frontal impacts between cars = 70 km/h
- Roads with no possibility of a side impact or frontal impact (only impacts with roadside infrastructure) = ≥100 km/h [19].
The Vision Zero design speeds were suggested based on best available evidence at the time, and allowed for at least a 10% risk of death. This has provided instrumental design guidance for rural and urban infrastructure and has been an important tool for justifying the transformations of the road transport system and in communicating with the community on the necessary changes. It is clear from reviewing road strategies around the world that the 30–50–70 km/h travel speed recommendation has been utilised from the late 1990s as a model of what constitutes a safe road transport system and is usually accompanied by indicative risk curves showing the exponential increase in risk with increased speed [20].
However, more recent research has shown that the early research around injury risk curves suffered from underreporting bias, overestimating the fatality risk for both pedestrians and car occupants [21]. While previous research suggested a 10% fatality risk for pedestrians at impact speeds of 30 km/h, Rosen and Sander [21] reported a fatality risk of only 2% at the same impact speed. However, Jurewicz et al. [22] estimated a 10% risk for a severe pedestrian injury (Maximum Abbreviated Injury Score 3+) to already be reached at a 20 km/h impact speed.
It can be concluded that travel speed alone is not a complete predictor of injury risk and that a change in velocity (delta-v) has a stronger connection to crash forces because of its dependencies on the acceleration level (negative) in the actual crash, and not only the travel speed prior to the crash. As travel speed in many crashes is not translated into the equivalent change in velocity, it can result in relatively flat risk curves compared to risk curves using delta-v, such as with the risk curve for single vehicle impacts [23].
While it can be a challenge to translate a risk curve using delta-v into advice on travel speed, it is necessary if the boundary conditions on human tolerance are to be translated into acceptable speed limits. A more precise relationship between crash forces and injury risk is given when deriving it as a function of closing speed, or the relative speed between two oncoming vehicles (e.g., for a car to pedestrian crash, impact speed and closing speed would be equal, while in a head-on crash the closing speed would be the sum of the impact speeds of the two approaching vehicles).
Even though this newer research indicates that while the previous advice on fatality risk as a function of travel speed might be somewhat misleading, the basic design speeds remain relevant if the scope is expanded to include the prevention of both fatal and serious injuries, especially when consideration is given to the older and more fragile segments of the population.
Under Vision Zero, the aim is to eliminate both fatalities and long-term health losses. While the earlier risk curves were concerned with only fatal injuries, new research considers the risk of serious injuries as well. To achieve zero, it will be necessary to determine this more precise relationship between delta-v and impact speeds to injuries for different crash types in order to be able to design a safe road system that is within the human tolerance and also meet the transport objective of the road system.
1.3. Safe Mobility and Accessibility
The main objective of a road network is to move people and goods. Many jurisdictions have in place a plan for safe and accessible mobility that details their approach to designing a transport system that meets the needs of those that use it, as well as the design purpose of each section of their road network [24]. Where available, these can be used to guide the types of safety interventions to be deployed to preserve the overall transport objectives of the system. Overlaying safety on an existing network plan can ensure that the countermeasures utilised are both safe and fit for the purpose of the different types of road environments and transport needs, and demonstrate how safe mobility can look in each network area. If safety is pushed forward without being able to sustain the movement function of the area this is less likely to be supported by government, as the transport objective of the network is not met.
In Victoria, Australia, Movement and Place (M&P) is the framework used for transport planning [24]. It is used to identify which roads serve what purpose and to define and operationalise the strategic objectives of achieving place, movement safety, and environmental outcomes. The M&P framework aims to balance the accessibility needs of different road users across the network and considers the community needs and expectations for the streets and places where they live, work, and pass through.
The M&P framework acknowledges that there are different modal priorities in different parts of the road network. The needs, requirements, and interventions needed to safety proof the area vary and the boundaries on how to make different parts of the network safe would be different. The challenge, then, is how to relate back to the Vision Zero objective on mobility being a function of safety, and how to overlay safety on the M&P framework to effectively manage the energy to within human crash tolerance levels to create a system that can move people around safely without the risk of dying or sustaining a serious injury.
1.4. Aims
This paper had three aims:
- To review the human tolerance to crash forces and compile a more precise relationship between delta-v and impact speeds and the level and risk of injury.
- To define the operational boundaries of what could constitute an Ultimate Safe System in 2050 that is both trauma-free and fit for its strategic transport purpose by utilising human tolerance as the key design factor. As many jurisdictions are aiming for zero by 2050 in their planning horizon, this was selected as the example year.
- To define the operational boundaries of what could constitute an Interim Safe System able to reduce the most severe injuries and contribute to trauma reduction by 2030, utilising human tolerance as the key design factor. As the UN has set a target of a 50% reduction in fatalities and injuries by 2030, this was selected as the example year.
Under an Interim Safe System, the most severe trauma would be prioritised for treatment first and beyond that, the system would be built upon to address any remaining serious trauma to arrive at an Ultimate Safe System that can prevent all fatal and serious road injuries. Using the state of Victoria, Australia as a case study, this study used back-casting methods on the pathway from 2050 to 2030 to the present and considered the outlooks at each time horizon to understand how to build on the countermeasures deployed to design and build an Interim Safe System and eventually an Ultimate Safe System.
2. Methods
2.1. Approach
This paper used human tolerance to injuries as the key design factor to define the combination of vehicle, infrastructure, and travel speed requirements to (1) prevent all fatalities and serious injuries by 2050 in an Ultimate Safe System scenario, and (2) significantly reduce fatalities and severe injuries by 2030 in an Interim Safe System scenario for Victoria, Australia based on its Movement and Place (M&P) framework objectives.
To determine the specific components of an Ultimate Safe System and Interim Safe System, the following steps were taken:
- Described the road trauma problem by crash types and road users in the different parts of the road network in the M&P framework for Victoria;
- Described the human tolerance per crash type and road user;
- Determined the infrastructure and vehicle countermeasures available to address the road trauma issues/crash types identified;
- Consulted the human tolerance for different crash types and determined the combination of infrastructure and vehicle countermeasures in conjunction with a maximum travel speed which together would be able to prevent all fatalities and serious injuries in an Ultimate Safe System scenario for each of the M&P areas;
- Consulted the human tolerance for different crash types and determined the combination of infrastructure and vehicle countermeasures in conjunction with a maximum travel speed which together would likely be able to significantly reduce fatalities and severe injuries in an Interim Safe System scenario for each of the M&P areas.
2.1.1. Identifying the Road Trauma Problem in M&P Network
Road trauma data for Victoria, Australia between the 2015/2016 and 2017/2018 financial years recorded in the Road Crash Information System (RCIS) online database were utilised to determine the road trauma problem in the different parts of the road network in the M&P framework. For this study, road trauma was limited to crashes involving motorised vehicles, thereby excluding single vehicle crashes with bicycles and micro-mobility devices such as e-bikes and e-scooters.
2.1.2. Compiling the Human Tolerance to Crash Forces
Currently, there is no globally accepted definition of what a serious road injury is, and this can create confusion in knowing what jurisdictions are aiming to prevent. To assist with defining the level of unacceptable serious injury to target, the type, severity, and length of injury were considered.
The Maximum Abbreviated Injury Score (MAIS) is often used as a measure of the level of injury sustained in a road crash, with a score of 0 to 6 where 0 is uninjured and 6 is considered a fatal injury. The group of MAIS 3+ injuries include more life-threatening injuries, such as severe brain injuries, amputations, paraplegia, quadriplegia, multiple rib fractures, complex fractures, and at the most severe end, injuries such as decapitation that guarantees a fatal outcome. Jurisdictions such as the European Union (EU) have identified MAIS 3+ injuries as the most essential consideration in trauma reduction and elimination in their interim targets [25]. However, when considering permanent health losses, injury types at the lower end of the MAIS, while not life threatening, can affect long-term quality of life. Injuries at the MAIS 2 level can include whiplash injuries, fractures, and concussions leading to cognitive issues and other injuries that can be debilitating and create a greater risk of long-term health impairment [26,27].
Based on these considerations, in this study a severe injury was defined as a life-threatening injury including any MAIS 3+ injury and/or any whiplash injury resulting in symptoms longer than six months in duration, and a serious injury was defined as any MAIS 2+ injury and/or any whiplash injury resulting in symptoms longer than one month in duration.
A review of the available research around the relationship between impact speed and injury, i.e., risk curves, was undertaken to understand the human tolerance boundaries to achieve a less than 10% risk of a serious injury for each of the crash types identified in the road trauma analysis in the M&P network under an Ultimate Safe System and a less than 10% risk of a severe injury under an Interim Safe System. The 10% was chosen on the basis of risk curves in general being challenging to interpret in the lower risk band due to the mathematical construction of the curve; thus, 0% was not a feasible choice.
2.1.3. Identifying Available Countermeasures
A list of currently available infrastructure and vehicle countermeasures that can address the crash types identified in the trauma analysis was developed based on a literature review and by reviewing available and upcoming New Car Assessment Programme (NCAP) protocols, technical specifications for vehicle standards, and manufacturers descriptions. This study only focused on currently available technologies and on preventing fatal and injury outcomes from the different crash types, rather than interventions that can address every identified risk factor.
According to Vision Zero principles, it is acknowledged that humans are fallible and thus any interventions that rely on human input and compliance lacks certainty and sustainability in achieving its intended effects. Countermeasures that are reliant on human input/compliance would require the user to execute some behaviour in order for the countermeasure to achieve its safety benefits. For example, a seatbelt reminder would only achieve its safety benefit if the occupant responds to its prompt by wearing the seatbelt; the vehicle could be driven regardless of the seatbelt wearing status. If the seatbelt was not worn despite a warning from the seatbelt reminder and a crash was to occur, the safety benefit of seatbelts would not be achieved. Similarly, while a tactile lane marking could alert a driver that they are departing the lane, it would require the driver’s input to correct the vehicle and not hit any dangerous objects outside of its lane. Conversely, countermeasures that are not reliant on human input/compliance can either enforce for the required behaviour to achieve the safety benefit or be independent of human behaviour in achieving the safety benefit. For example, a seatbelt interlock would enforce for seatbelt wearing by not allowing the vehicle to be moved unless occupants are belted; thus, if a crash was to occur, the safety benefits of seatbelts would be achieved. Similarly, a wire rope barrier would physically ensure the vehicle will not hit any dangerous objects outside of its lane regardless of what the driver’s behaviour may be.
Therefore, the countermeasures in this section were separated into two lists, those that rely on human input/compliance and those that do not, in order to achieve the intended safety outcome. To be included on the list, the countermeasures must be available and have demonstrated effectiveness in reducing real life crashes and injuries, or else have shown a potential in reducing injuries through simulations or predictive studies on their target crash population.
A literature review was conducted for each countermeasure on effectiveness in reducing road trauma. The design and boundary limitations of each countermeasure were documented as well.
- Vehicle Safety Countermeasures
The report ‘In depth cost-effectiveness analysis of the identified measures and features regarding the way forward for EU vehicle safety’ was commissioned by the EU to assess the benefit and feasibility of a range of vehicle safety technologies, which led to the amendment of the General Safety Regulations [28]. For the report, a comprehensive literature review was undertaken, with studies being included based on quality of research, quality of data, timeliness, and relevance. The review included studies from around the world and the level of effectiveness would be applicable to the Australian context. Where available in the EU report, the studies that were included as a part of the report’s effectiveness assessment were used as the basis of effectiveness for vehicle safety technologies in this current study.
- Road Infrastructure Countermeasures
Austroads is the main organisation of Australasian road transport and traffic agencies and regularly publishes reports and guides to promote a nationally consistent approach to road design, maintenance, and operation. Literature reviews of effectiveness and parameters of operation (where available from Austroads) were used as the basis of effectiveness for road infrastructure countermeasures in this study.
For the remaining countermeasures, the databases Science Direct, EBSCOhost, and MEDLINE were utilised to search for research indicating the effectiveness of the countermeasure. A scan of the resulting articles was conducted, and the following criteria used to select the supporting article for this study:
- Utilise Australian based studies of effectiveness where available;
- Utilise meta-analyses of effectiveness where available;
- Utilise studies with real world data where available.
Related articles sourced from the primary article were reviewed where relevant.
An internet search was conducted to identify any relevant grey literature, and was limited to official reports and guidelines, conference proceedings, and information with credible sources and references.
2.1.4. Determining an Ultimate and Interim Safe System
To determine the combination of vehicle, infrastructure, and travel speed requirements for each part of the M&P road network to create an Ultimate Safe System in 2050 and an Interim Safe System in 2030, the following were considered:
- The transport function of the area;
- The key trauma issues of the area;
- The human tolerance boundaries.
The combination of vehicle and infrastructure measures were selected based on the different trauma problems in the area and whether the intervention was able to address the particular crash types in the area and to reduce the risk of injury to the tolerance levels specified in Table 1.
Table 1.
Delta-v and Impact Speed with a 10% risk for serious and severe injury for different crash types.
For an Ultimate Safe System, countermeasures were selected from the list that did not rely on human input or compliance (NRHIC) in order to guarantee the intended outcome as much as possible whenever there was an available and effective intervention for the crash type. Countermeasures were only selected from the human intervention or compliance required (RHIC) list if there were no viable alternatives available on the NRHIC list while ensuring, in combination with other NRHIC countermeasure and the travel speed, that any crash would be within human tolerance and not result in a fatality or serious injury. The threshold for injuries to be considered unacceptable was defined as a 10% risk of a serious injury (MAIS 2+ or whiplash injury greater than one month duration).
For the Interim Safe System, countermeasures were selected from either list, and the threshold for injuries that could result in a permanent health loss was defined as a 10% risk of a severe injury (MAIS 3+ or a whiplash injury greater than six months duration).
To determine what was a safe travel speed, all the components of the system that controls crash forces and injury risk, both road infrastructure and vehicle, were considered. For example, with autonomous emergency braking (AEB) on vehicles the acceptable travel speed could be determined by the acceptable closing speed (or impact speed) plus the speed of which the vehicle can reduce by braking prior to impact. This approach was used by Eugensson et al. [29] to define the boundary conditions for a safe road transport system in 2020, and this is the approach used in this study when setting the boundary condition for the Ultimate and Interim Safe System as well. In addition, many vehicle and infrastructure measures are designed to be effective within certain travel speeds (e.g., lane-keeping assist activates at 60 km/h and above, traffic calming is designed for areas with travel speeds ≤50 km/h), and these boundaries of effectiveness for each countermeasure were considered when deciding which countermeasures to specify for an area and the appropriate travel speed to overlay on it.
The human tolerance boundaries in Table 1 were consulted when selecting the countermeasures and the speed to specify and again to confirm the final combination of vehicle, infrastructure, and travel speed requirements decided on to meet the desired tolerance levels.
3. Results
3.1. Road Trauma Problem in M&P Network
There are six street families under M&P, classed as civic hubs, city streets and city places, activity streets, local streets and connectors. In this paper, the street families were combined into three categories based on their safety need commonalities:
- Pedestrian priority areas = civic hubs, city streets and city places;
- Mixed traffic areas = activity streets;
- Vehicle priority areas = connectors and local streets.
Transport Function
The main transport functions for each of the street family categories according to the M&P are detailed below. It should be noted that the M&P currently does not specify a recommended or allowable travel speed in each movement area.
Pedestrian Priority Areas
The main transport purpose and function of pedestrian priority areas is to give priority to pedestrian movement and safety in a pedestrian friendly environment. There is high pedestrian movement and numbers and the objective is to support on-street activity and public life while connecting with the wider transport network. Pedestrians are encouraged to walk and move around freely and the aim is for them to both feel and be safe in doing so. While ideally this would be a vehicle-free zone, limited vehicle access for accessibility reasons (e.g., taxis, buses) may be required [24].
Mixed Traffic Areas
Mixed traffic areas have a high demand for movement and place that provides access to shops and services by all modes. There is a strong focus on supporting neighbourhood life and residential streets as well as businesses. There is a need to balance all these demands within the space that is available, and there are competing demands between vehicles and other road users [24].
Vehicle Priority Areas
The main transport function of roads and transport links in the vehicle priority areas is the efficient movement of people and goods between regions, and this necessitates a certain level of travel speed to achieve this function efficiently. It includes local streets that should foster a community spirit as well as local access [24].
Trauma Analysis
The analysis showed that 80.8% of all fatalities and serious injuries (FSI) (where serious injury is defined as hospitalisation by the Victorian Government) occurred in the vehicle priority areas, followed by 11% in mixed traffic areas and 4.6% in pedestrian priority areas. While vehicle occupants dominated the FSI in all areas, pedestrian FSI were most prevalent in the pedestrian priority areas by proportion (see Figure 1). All the identified crash types (pedestrians, intersection, head-on, rear-end, manoeuvring, overtaking, on path and run-off road) occurred in each of the street categories in different proportions, as seen in Figure 2.
Figure 1.
Road user FSI by M&P.
Figure 2.
Crash types by M&P.
3.2. Human Tolerance for Fatalities, Severe and Serious Injuries
The results from the risk curve review are displayed in Table 1, showing the impact speed and delta-v for different crash types at which the road user would be subjected to a 10% risk of a serious or severe injury.
For pedestrians, Rosen and Sander [21] estimated that the 10% risk for an MAIS 3+ injury was at an impact speed of 30 km/h. However, if age was considered, Rosen [30] showed that for the age group 60 years and above, the 10% risk was estimated at 20 km/h. Jurewicz et al. [22] estimated the 10% risk for an MAIS 3+ injury to be at a 20 km/h impact speed. If a lower risk level is considered, it has been shown that even contact with the ground from a fall following a low-speed impact with a vehicle could result in a serious pedestrian injury. Hence, in an Ultimate Safe System, no motor vehicle and pedestrian collisions can be allowed. The same risk curves for pedestrians were assumed to be relevant for bicyclists.
For motorcycles, Ding et al. [31] derived risk curves for MAIS 2+, MAIS 3+ and fatal injuries as a function of impact speed for helmeted riders. The 10% risk of MAIS 2+ and MAIS 3+ injury for a crash into a wide object was estimated to be 25 km/h and 50 km/h, respectively, while risk of a serious and severe injury into a narrow object far exceeds 10% at any impact speed. The 10% risk level in a ground impact was only possible to estimate for MAIS 3+ injuries at 75 km/h.
With side impacts, more recent risk curves from the German In Depth Accident Study (GIDAS) [32] showed a 10% risk for MAIS 2+ and MAIS 3+ injuries at 20 km/h and 30 km/h lateral delta-v and 40 km/h and 60 km/h impact speeds, respectively. The risk was determined to be equal for car to heavy vehicles collisions regarding delta-v, which would naturally result in a lower allowable impact speed due to the mass difference.
For head-on frontal collisions, Doecke et al. [23] estimated a 10% risk of a MAIS 3+ injury at 53 km/h impact speed (half the closing speed) based on United States event data recorder (EDR) data. Autoliv [32] estimated the same 10% risk of a MAIS 3+ injury to be at 50 km/h delta-v, which would be the same as an impact speed in a head-on collision with a vehicle of equal mass. The same study using GIDAS data showed a 10% risk for an MAIS 2+ injury at 25 km/h delta-v. Similar results have been shown using Swedish and US EDR data [33,34]. The same logic was used to set the delta-v and impact speed for car to heavy vehicle frontal impacts as for side impacts.
For rear-end impacts the MAIS levels were not relevant, as the most dominant permanent impairing injury would be a whiplash injury as a result of mostly non-life-threatening injuries. Instead, the 10% risk of a serious and severe injury was based on symptoms for more than one month duration and symptoms for more than six months duration, respectively. Krafft et al. [35] showed a 10% risk of a serious whiplash injury to be approximately 10 km/h delta-v (20 km/h impact speed) and 20 km/h delta-v (40 km/h impact speed) for a severe whiplash injury. The impact speed in car to heavy vehicle crashes was divided by two in the case of head-on and side impacts.
There were no relevant risk curves for side impact into fixed narrow objects to estimate a 10% risk for a serious or severe injury. The Australasian New Car Assessment Programme carries out side impact pole tests for vehicles at an impact speed of 32 km/h [36], and thus 30 km/h was used as a proxy as the maximum allowable impact speed for a serious injury.
3.3. Available Countermeasures
The available countermeasures for infrastructure and vehicles, both reliant and not reliant on human input and compliance, are specified in Table 2 and Table 3. Further information on the boundary conditions and literature of effectiveness for each countermeasure can be found in Appendix A.
Table 2.
Infrastructure Safety Countermeasures by reliance on human input/compliance.
Table 3.
Vehicle Safety Countermeasures by reliance on human input/compliance.
3.4. Designing an Ultimate and Interim Safe System
3.4.1. Pedestrian Priority Areas
The key trauma focus in pedestrian priority areas was car to pedestrian impacts. From Table 1, it is understood that no level of impact is considered safe for pedestrians if aiming to eliminate serious injuries. In a vehicle free zone, the possibility of conflict, and thus the risk of any injury, is eliminated. However, if vehicles are allowed the risk will need to be managed through the deployment of safety countermeasures. The combination of vehicle and infrastructure interventions in conjunction with travel speed limits must be able to eliminate the risk of serious injury altogether in an Ultimate Safe System (refer to Table 4).
Table 4.
Ultimate Safe System in 2050 for Pedestrian Priority Areas.
AEB pedestrian is currently being assessed by NCAPs on their ability to avoid impact with a pedestrian at speeds up to 40 km/h and ability to reduce impact speed by at least 20 km/h at travel speeds up to 60 km/h [37]. The vehicle’s ability to avoid a pedestrian collision is, however, dependent on the Time To Collision (TTC), which is the time it takes the AEB system to detect the pedestrian. TTC would vary depending on the environment. In a longitudinal setting, where a vehicle is approaching a pedestrian in the same direction without sight obstruction, a Forward Collision Warning needs to be issued before a TTC of 1.7 s for the vehicle to be awarded points in the NCAP assessment [37]. Where the vehicle is able to detect and brake with a TTC around 2 s, it is assumed that a travel speed of at least 40 km/h is possible without the risk of a pedestrian collision. However, in a highly pedestrianised area or in an environment with many potential obstructions the TCC will be much lower. For example, a child running into the traffic lane from behind a parked vehicle would result in a TTC of less than 0.5 s. With such a low TTC, AEB will at most be able to remove 10–15 km/h off the impact speed in normal conditions on dry asphalt.. Therefore, it will be necessary to set the maximum travel speed limit at 10 km/h to guarantee crash avoidance with a pedestrian in pedestrian priority areas. Road surface friction that can guarantee effective performance of AEB under all weather conditions including ice and snow will be required under all circumstances.
To ensure the speed is complied with, the vehicle should be equipped with limiting Intelligent Speed Assistance (ISA). From an infrastructure perspective, fully separated lanes for bicycles and micro-mobility devices (e.g., e-bicycles and e-scooters) outside of pedestrianised areas will remove conflict between vehicles and bicyclists/micro-mobility devices. These measures together will create an environment that has less than a 10% risk of a serious injury for all road users. For all the other crash types identified in Figure 2, even without additional vehicle features, a travel speed of 10 km/h, enforced by limiting ISA will not create forces that exceed the human tolerance in any scenario in an Ultimate Safe System.
In an Interim scenario (refer to Table 5), a higher level of injury is accepted, and thus even with less stringent requirements, such as higher travel speeds and advisory ISA in combination with traffic calming measures, could still greatly reduce the risk of severe injuries to 10%, but not be able to remove the risk of a serious injury altogether. However, limiting ISA would still be preferable in an interim scenario, as it can enforce for the maximum speed even without additional infrastructure support. AEB rear-end was added because while a travel speed of 30 km/h would be within the tolerance levels of a severe injury if a crash was to occur, compliance with the travel speed requirement cannot be ensured with only advisory ISA and traffic calming measures. Therefore, additional vehicle technologies are required to help decrease the risk of a severe injury in a rear end impact if ISA limiting is not in use. A travel speed of 30 km/h was set and if complied with, and if any of the crash types identified in Figure 2 were to occur, they would not exceed the human tolerance for a severe injury.
Table 5.
Interim Safe System in 2030 for Pedestrian Priority Areas.
From the crash data, motorcycle to pedestrian crashes were rare and there were no risk curves that could be used to estimate the level of risk, therefore it is assumed that motorcycle to pedestrian crashes can be reduced in the Interim scenario with the combination of measures specified.
3.4.2. Mixed Traffic Areas
The key trauma risks in mixed traffic areas were identified as car to pedestrian impacts, head-on crashes and side impact crashes at intersections. While the M&P framework does not specify speed limits for the street areas, other urban street design guides (e.g., Global Designing Cities Initiative) provide guidance on speed limits for safety and liveability. For urban areas, it is recommended that the speed limit does not exceed 40 km/h [38]. To ensure that a speed of 40 km/h is within human tolerance in an Ultimate Safe System, vehicles will need to be equipped with AEB pedestrian, AEB head-on, AEB rear-end, limiting ISA and other technologies. AEB pedestrian will be able to effectively prevent a collision with a pedestrian if the TTC is 2 s or greater with no obstruction to sightline; this can be achieved in combination with pedestrian crossings with a travel speed of 10 km/h and limiting ISA to ensure the speed is complied with (refer to Table 6).
Table 6.
Ultimate Safe System in 2050 for Mixed Traffic Areas.
If a pedestrian was to cross outside of the designated pedestrian crossing, their risk of a serious injury must be eliminated under an Ultimate Safe System. To do this, sidewalks must be designed with sufficient distance from the closest road lane to ensure AEB pedestrian can detect and react to a pedestrian attempting to enter the road lane. In a worst-case scenario with a running pedestrian, a distance of around 5 m would be required for a vehicle at 40 km/h to avoid impact (assuming a running speed of 10 km/h and that the car would require approximately 1.5–2 s to stop from a speed of 40 km/h). Otherwise, pedestrian fencing can be considered to ensure no pedestrian access outside of the designated pedestrian crossing areas. However, in a mixed traffic area where liveability and accessibility for pedestrians is a priority, consideration will have to be given to whether fencing would fit within the type of environment the transport objectives would prefer to achieve for the area.
Frangible narrow roadside objects/and or removal of hazardous narrow roadside objects will be required to ensure any side impact into narrow objects are either avoided or the impacted object is frangible so the impact is less than 30 km/h due to unexpected events such as a tire puncture.
To ensure side impact collisions in an Ultimate Safe System are within the tolerance level of an impact speed and delta-v of 20 km/h to protect against serious injury, speed at intersections must be reduced to 20 km/h and enforced by limiting ISA. Fully separated lanes outside of pedestrianised areas will need to be provided in order to help remove conflict between vehicles and bicyclists/micro-mobility devices.
In an Ultimate scenario, heavy vehicles cannot be accommodated in the mixed traffic area if the travel speed needs to be preserved at 40 km/h due to the movement function of the road. At this travel speed, head-on crashes involving heavy vehicles will exceed the tolerance limit and therefore alternate route planning for heavy vehicle through traffic via vehicle priority areas will be required.
Under an Interim Safe System scenario (refer to Table 7), the higher accepted injury threshold would enable some less stringent requirements as compared to the Ultimate Safe System, which include:
Table 7.
Interim Safe System in 2030 for Mixed Traffic Areas.
- Advisory ISA instead of limiting ISA, although limiting ISA would still be the preference where possible;
- A minimum of 2 m distance from sidewalk to closest road lane to avoid high severity car-to-pedestrian collisions based on a person running into traffic or pedestrian fencing to prevent access;
- 30 km/h for pedestrian crossing instead of 10 km/h;
- Utilising roundabouts to reduce impact angle severity and to slow vehicles down to the tolerance level for severe injuries in side impact crashes;
- Addition of traffic calming measures to encourage higher levels of speed compliance.
For both the Ultimate and Interim Safe System, the defined vehicle, infrastructure and speed requirements will be able to effectively manage the energy in the system to the defined acceptable tolerance levels for the remaining crash types identified in Figure 2.
3.4.3. Vehicle Priority Areas
The key crash types in vehicle priority areas were head on, run off road, rear end, and side impact crashes. Head on and run off road crashes can be managed with full continuous flexible side and mid barriers to remove the risk of these resulting in a serious injury risk. In an Ultimate Safe System (refer to Table 8), vehicle technologies such as lane keep assist and emergency lane keeping alone or even in combination with other infrastructure measures such as a centre line would not be sufficient to ensure safety due to the possibility of tire punctures and other unexpected events that can result in unintentional lane departure and loss of control, which exceeds the boundaries of what the technologies were designed to address. In addition, head on crashes with heavy vehicles can only tolerate a very low delta-v; barriers can effectively prevent this conflict.
Table 8.
Ultimate Safe System in 2030 for Vehicle Priority Areas.
Similarly, with side impact crashes at intersections grade separation can remove the conflict altogether and thus the injury risk. Otherwise, the installation of roundabouts with a speed limit of 20 km/h at intersections, enforced with limiting ISA can ensure any crash impacts are within human tolerance for a serious injury.
For unsealed roads where authorities are not motivated to make any infrastructure improvements due to the low volume of traffic, vehicle technologies alone will not be sufficient to ensure safety from serious injury without a significant reduction in travel speed in an Ultimate Safe System. For example, AEB head-on can reduce closing velocity by 30 km/h on average [39]; however, with lower friction on unsealed roads the effectiveness would be significantly reduced. To prevent head on serious injury risk, the maximum travel speed needs to be 30 km/h or lower to allow AEB head on, as well as other AEB technologies for other crash types, to work effectively. Otherwise, the alternative will be to close the road and re-route traffic to other nearby safer roads where safety can be guaranteed.
Where pedestrians and bicyclists are allowed access, pedestrian grade separation and off-road bicycle paths need to be provided.
Motorcyclists are inherently vulnerable due to the lack of protection and currently cannot be safely accommodated with other vehicles in the mixed traffic area in an Ultimate Safe System due to no available countermeasure that can guarantee the use of a motorcycle helmet. Without a helmet, the risk will exceed the human tolerance and motorcyclist safety cannot be assured. In an Interim scenario, dedicated motorcycle routes away from other vehicles could reduce their risk of severe injury to within tolerance levels, assuming helmets are worn and enforced for.
In an Interim scenario (refer to Table 9), barriers will still be needed to reduce the risk of a severe injury due to the high-speed environment necessitated by the M&P function. Where continuous barriers cannot be motivated, continuous line markings coupled with lane keep assist/emergency lane keep, with targeted flexible barriers at high-risk locations (e.g., where hazardous objects such as trees, cliffs, mountains in close proximity to the road) will be a necessary minimum to keep crash energies to within a severe injury tolerance. For side impact crashes, well designed roundabouts or raised intersection platforms will be required to bring any impacts to within the tolerance level if grade separation is not used.
Table 9.
Interim Safe System in 2050 for Vehicle Priority Areas.
3.5. Minimum Vehicle Requirements for the Fleet in 2030 and 2050
To achieve zero road trauma and a reduction in the most severe injuries by 2050 and 2030, respectively, the overall fleet must comprise of vehicles equipped with certain safety features that can help prevent or mitigate injuries.
From the combination of vehicle, infrastructure, and travel speed requirements defined for the pedestrian priority, mixed traffic, and vehicle priority areas to achieve an Ultimate and an Interim Safe System, the minimum vehicle technology requirements at 2030 and 2050 are as shown below in Table 10 and Table 11.
Table 10.
Minimum vehicle technology requirements at 2030.
Table 11.
Minimum vehicle technology requirements at 2050.
In addition to the vehicle safety technologies specified for 2030 and 2050, the crash protection features of the vehicles need to be of a high standard, and as a minimum, meet all the priority vehicle safety regulations set out under Target 5 of the UN Global Road Safety Performance Target for vehicles, which states:
- Target 5–By 2030, 100% of new (defined as produced, sold or imported) and used vehicles meet high quality safety standards, such as the recommended priority UN Regulations, Global Technical Regulations, or equivalent recognized national performance requirements [40].
The recommended priority UN regulations include:
- UN Regulation 94 Frontal Impact
- UN Regulation 95 Side Impact
- UN Regulation 140 (GTR 8) Electronic Stability Control
- UN Regulation 127 (GTR 9) Pedestrian Protection
- UN Regulation 16 Seat Belts
- UN Regulation 14 Seat Belt Anchorages
- UN Regulations 44/129 Child Restraints
- UN Regulation 78 (GTR 3) Motorcycle ABS
Currently, the only priority regulation Australia is lacking is for pedestrian protection [41]. These minimum regulations need to be regulated for by the target dates. For maximum protection, all vehicles and specified technologies must be of a 5-star ANCAP safety standard according to 2030 and 2050 assessment protocols. In addition, heavy vehicles including buses and trucks should not be allowed to raise the height of the vehicles or fit bull-bars in order to further increase the safety for all road users.
4. Discussion
A number of jurisdictions globally have set a zero road fatalities and serious injuries target by 2050 and an interim 50% reduction in road trauma by 2030. This study set out to investigate how the road system would need to look in order to achieve this, and whether such a safe system is possible to construct with currently available road safety measures. This was achieved by defining the operational boundaries of what could constitute an Ultimate Safe System able to eliminate road trauma in 2050 and an Interim Safe System able to reduce the most severe trauma in 2030 by utilising the known human tolerance to crash forces as the key design factor.
Utilising a back-casting approach, the vehicle, infrastructure and travel speed requirements were defined to effectively manage crash energy to within the human tolerance to achieve an Ultimate Safe System. It is acknowledged that the design boundaries of an Ultimate Safe System in its entirety are very far from where the current Victorian road transport system is, and the transformation required to achieve an Ultimate Safe System is significant. However, it was important to define the Ultimate Safe System free from considerations of political will, willingness to invest, cost, pragmatism, and community acceptance, as this step was to determine whether an Ultimate Safe System that can achieve its objective of zero trauma is actually feasible with the currently available countermeasures. This allowed for more creative thinking based on the desired end goal and available evidence rather than being restricted by present limitations. The result of this process clearly defined how such a system would need to look and the likely effort needed in order to achieve zero road trauma. Discussions on willingness to invest and build such a system can then be well-informed and based on a clear understanding of the scale of work that needs to be undertaken.
The results from this study demonstrated that by using human tolerance as the key design factor, with the vehicle and infrastructure countermeasures currently available coupled with appropriate travel speeds it is possible to construct an Ultimate Safe System that can manage crash forces to achieve zero trauma in Victoria, Australia. While these results will require further validation, indications are that there is no need for jurisdictions to await further technological advancements such as autonomous vehicles to reduce and even eliminate road trauma. Developments such as autonomous vehicles and connectivity may show promise in helping reduce trauma, however, the penetration of these features can take up to 30 years from the year of regulation [42], and is thus too slow to make a significant difference in the fleet to help achieve any targets set for 2030 or even 2050. With only the currently available interventions listed in this study, jurisdictions can already make significant changes to the road network to systematically remove risks and begin building an Interim Safe System to reduce the most severe trauma before moving towards building an Ultimate Safe System that can achieve zero; however, substantial implementation of known measures is currently lacking. With strategy planning often occurring in cycles of 3–5 years, the politics of committing to a zero goal is difficult when key decision makers do not expect to be in power when the results of the strategy are due. A long-term transformational plan to move towards zero trauma, as demonstrated in this study, has the value to leverage long-term commitment to ensure that actions are undertaken promptly.
To move from a mainly casualty reduction-based strategy to a transformational strategy may be considered too optimistic by jurisdictions without a bridging step. Therefore, this study back-casted from an Ultimate Safe System to an Interim Safe System that is able to reduce the most severe injuries in the system by 2030. In this pathway, the most severe injuries and fatalities will be addressed first from the current state up to 2030, before continuing to transform the system to an Ultimate Safe System that will eventually be able to eliminate the remaining fatalities and serious injuries by 2050. This approach demonstrated the stages and interventions required for a systematic and sustainable pathway from the current road trauma to an interim stage and finally to the ultimate goal of zero trauma.
It is important to note the combination of measures specified under the Ultimate and Interim Safe System was considered from a system perspective and must be implemented as a package in order to derive the intended trauma reduction/elimination outcome. The combination of vehicle and infrastructure treatments selected along with the maximum travel speeds have a synergistic effect, and if one measure exceeds the boundaries set it will affect the effectiveness of the other measures specified as well. For example, if the travel speed is too high, this might exceed the envelope of effectiveness for AEB and the technology will not work as intended. The safety outcome in an Interim Safe System scenario cannot be guaranteed due to the use of less stringent vehicle and infrastructure measures that are in part reliant on human input/compliance (e.g., seatbelt reminder systems) to achieve the intended safety outcome. Therefore, in an interim scenario, road user programmes such as police enforcement will still be required to motivate compliance with road rules.
Movement and Place was used in this paper as a tool for implementation and determination of which countermeasures would be relevant where in the road network. The Vision Zero principle of movement as a function of safety has long been used as an argument to reduce speed limits where the infrastructure is not adequately designed to protect road users. Alternatively, safety can be achieved by keeping the speed limit constant on roads with a high movement function by implementing infrastructure improvements. However, jurisdictions rarely have the resources to make transformational changes to the majority of the road network. Hence, guidance is needed on where to prioritise investments. The results of this study showed that by being clear on the movement or place function in different areas in the road network and adopting safety solutions targeting the modal priority it is possible to achieve a safe system for all modes of transport. It is therefore recommended that jurisdictions that plan to achieve zero fatalities and serious injuries should adopt available tools for transport and land use planning, followed by a clear definition of how safety is guaranteed in each of the areas of the transport network by utilising human tolerance as the key design consideration.
Ideally, a safe road system will be able to safely accommodate all modes of road users. In this study, it proved difficult to ensure the safety of motorcyclists, and thus their inclusion in an Ultimate Safe System. Motorcyclists are inherently vulnerable due to their lack of protection and their ability to travel at high speeds, and there are currently a limited number of countermeasures that can effectively improve their safety. The risk curves of injury risks for motorcyclists are for helmeted riders, with the assumption that injury for non-helmeted riders would far exceed the tolerance levels specified for serious injuries. As there is currently no intervention that can guarantee helmet wearing, and thus ensure crash forces will be within human tolerance levels for a serious injury, at this point in time motorcyclists cannot be safely accommodated in an Ultimate Safe System. In an Interim Safe System, motorcycle-dedicated routes to reduce car to motorcycle conflicts, as well as enforcing helmet wearing and protective clothing, would be needed in order to help reduce motorcycle trauma. However, a large gap in knowledge exists on how to move from an Interim scenario to an Ultimate scenario where motorcyclists can be safely accommodated, and further research and innovative measures in this area are needed.
Similarly, in an Ultimate scenario, heavy vehicles cannot currently be safely accommodated in the mixed traffic area. However, alternate route planning for heavy vehicle through traffic via vehicle priority areas can still allow heavy vehicle access. In regards to delivery of goods to businesses in the mixed traffic area, alternate vehicle choices such as light duty vehicles may need to be considered.
4.1. Implications for Road Safety
The Global Plan [6] published as a guiding document for the second Decade of Action for Road Safety sets out the recommended actions for jurisdictions in the coming decade, however, it does not provide guidance on the prioritisation of actions for the short or long term to achieve trauma reduction. The guidance is necessarily broad rather than specific due to the global audience of the document, and the results and processes undertaken from this study can be a useful accompaniment to the Global Plan for jurisdictions that would prefer a more detailed pathway to trauma reduction.
The results from this study set out a clear pathway from the current road trauma problem to an Interim Safe System that can reduce the most severe injuries by 2030 to an Ultimate Safe System that can achieve zero road trauma by 2050. It was based on the Victorian trauma problem and its overriding M&P transport plan. It is acknowledged that what would constitute an Ultimate and Interim Safe system in other jurisdictions with different trauma profiles and transport priorities might be different. However, the steps taken in this study to arrive at an Interim and Ultimate Safe System are equally applicable to other jurisdictions, as the human tolerance to injuries compiled is universally applicable, as are the majority of the specified countermeasures. Jurisdictions can undertake a similar process to determine the short- and long-term system requirements to achieve their desired targets and begin implementation to close the gap between their current road safety situation and their defined Interim and Ultimate Safe Systems.
4.2. Limitations
Currently, there is no clear definition of what a serious injury is. This is a limitation for global strategy development as well as for this study, as it is unclear exactly what it is that jurisdictions are aiming to prevent. The specification of human tolerance and the Ultimate Safe System are both dependent on having a clear definition. This paper defined a serious injury as a 10% risk of a MAIS 2+ injury or an injury with symptoms sustained for longer than one month duration. This is likely to be a conservative estimate, as the Ultimate Safe System aims to prevent all MAIS 2+ injuries regardless of whether the injury is permanent or not. Further research on where and how these injuries occur would allow for system designers to more effectively safeguard the system against them. Any adjustment in the definition of a serious injury would also adjust the Ultimate Safe System and the combination of measures required to construct the ultimate scenario.
There is a gap in the literature regarding the risk of injury for motorcycle to pedestrian crashes, single bicycle crashes, single micro-mobility device crashes, and crashes between these groups of road users. Without the relevant risk curves and profiles, it was not possible to specify an Ultimate Safe System or Interim Safe System that can systematically reduce their risk of injury. This paper only focused on preventing motorised vehicle-related crashes; however, as more research becomes available, the systems can be evolved to also incorporate the safety of these types of crashes.
The vehicles, infrastructure and travel speed requirements set for the Ultimate and Interim Safe Systems were based on the human tolerance to crash forces before the risk of serious, severe, and fatal injuries increase. It assumed that the interventions are effective within the limits of their boundary conditions. However, if the boundaries change or are exceeded, the risk levels will change. One example would be the friction available for braking on roads covered with snow and ice, or sensor performance in foggy and rainy conditions. This needs to be accounted for either by the road agency guaranteeing certain conditions, or more likely, by vehicles adapting their speed to the current conditions. Technological advancements are expected to be made in the near future, especially in regards to vehicle technologies. Where newer specifications are available, the boundaries and specifications of the system can change. For example, if AEB systems can automatically detect whether there are pedestrians at a crossing, the vehicle can automatically slow to 10 km/h or continue at the speed limit if there are no pedestrians present, rather than specifying a blanket 10 km/h requirement at all pedestrian crossings at present. As newer specifications become available, the system requirements can be updated.
Currently, the vehicle and infrastructure measures specified are assumed to be 100% effective for a particular crash type if all the boundary conditions are met (see Appendix A). However, there may be gaps in effectiveness based on real world data that would necessitate further technological developments to ensure effectiveness. In the Interim scenario, compliance is assumed rather than strictly enforced for, unlike the Ultimate scenario; thus, the trauma reduction outcome would only be achieved if the system requirements specified are complied with. Additional measures such as police enforcement may be required in the interim stage to further secure the target trauma reduction desired. Further validation of this study utilising real-world data is required to identify any gaps in the technical specifications. Modelling how closely the specified systems match the intended targets and identifying any residual trauma not already addressed in the system are additional requirements.
4.3. Next Steps
The next step will be to validate the specifications from this study by using a sample of real-world crashes to model how close the systems specified here are to the intended targets, identify any residual trauma in the system not already addressed, and plan how to optimally implement the systems.
Author Contributions
Conceptualization, J.T. and J.S.; writing—original draft preparation, J.T. and J.S.; review and editing, J.T., J.S., R.F.S.J., D.B.L. and S.N.; supervision, R.F.S.J., D.B.L. and S.N. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
All data exist in the paper as published.
Conflicts of Interest
The authors declare no conflict of interest.
Appendix A. Currently Available Infrastructure and Vehicle Countermeasures
Table A1.
Infrastructure and vehicle countermeasures not reliant on human input/compliance.
Table A2.
Infrastructure and vehicle safety countermeasures reliant on human input/compliance.
References
- United Nations General Assembly. In Proceedings of the Improving Global Road Safety Resolution A/RES/74/299 74th Session, New York, NY, USA, 31 August 2020.
- Victorian Government. Towards Zero 2016–2020 Strategy and Action Plan; Victorian Government: Melbourne, VIC, Australia, 2016.
- Job, R.F.S.; Truong, J.; Sakashita, C. The Ultimate Safe System: Redefining the Safe System Approach for Road Safety. Sustainability 2022, 14, 2978. [Google Scholar] [CrossRef] [Scilit]
- Salmon, P.M.; Read, J.M. Many model thinking in systems ergonomics: A case study in road safety. Ergonomics 2019, 62, 612–628. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kechagias, E.P.; Miloulis, D.M.; Chjatzistelios, G.; Gayialis, S.P.; Papadopoulos, G.A. Applying a system dynamics approach for the pharmaceutical industry: Simulation and optimization of the quality control process. WSEAS Trans. Environ. Dev. 2021, 17, 983–996. [Google Scholar] [CrossRef] [Scilit]
- World Health Organization; United Nations Regional Commissions. Global Plan Decade of Action for Road Safety 2021–2030; WHO: Geneva, Switzerland, 2021. [Google Scholar]
- Cameron, I.; Ward, D.; Hakkert, A.S.; Weijermars, W.; Larsson, P.; Brodie, C.; Kloth, M. Zero Road Deaths and Serious Injuries: Leading a Paradigm Shift to a Safe System; OECD Publishing: Paris, France, 2016. [Google Scholar]
- Lie, A.; Tingvall, C.; Krafft, M.; Kullgren, A. The effectiveness of electronic stability control (ESC) in reducing real life crashes and injuries. Traffic Inj. Prev. 2006, 7, 38–43. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Erke, A. Effects of electronic stability control (ESC) on accidents: A review of empirical evidence. Accid. Anal. Prev. 2008, 40, 167–173. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Ohlin, M.; Strandroth, J.; Tingvall, C. The combined effect of vehicle frontal design, speed reduction, autonomous emergency braking and helmet use in reducing real life bicycle injuries. Saf. Sci. 2017, 92, 338–344. [Google Scholar] [CrossRef] [Scilit]
- Sternlund, S.; Strandroth, J.; Rizzi, M.; Lie, A.; Tingvall, C. The effectiveness of lane departure warning systems-A reduction in real-world passenger car injury crashes. Traffic Inj. Prev. 2017, 18, 225–229. [Google Scholar] [CrossRef] [Scilit]
- Gayialis, S.P.; Kechagias, E.; Papadopoulos, G.A.; Konstantakopoulos, G.D. Design of a Blockchain-Driven System for Product Counterfeiting Restraint in the Supply Chain. In Proceedings of the IFIP International Conference on Advances in Production Management Systems (APMS), Austin, TX, USA, 1–5 September 2019; pp. 474–481. [Google Scholar]
- Kechagias, E.; Gayialis, S.; Konstantakopoulos, G.D.; Papadopoulos, G. An Advanced Routing and Scheduling System for Dangerous Goods Transportation. In Proceedings of the 8th International Symposium and 30th National Conference on Operational Research, Patras, Greece, 16–18 May 2019. [Google Scholar]
- Strandroth, J.; Moon, W.; Corben, B. Zero 2050 in Victoria—A Planning Framework to Achieve Zero with a Date. In Proceedings of the World Engineering Convention Australia, Melbourne, Australia, 20–22 November 2019. [Google Scholar]
- Robinson, J.B. Unlearning and Backcasting: Rethinking some of the questions we aks about the future. Technol. Forecast. Soc. Changes 1988, 33, 325–338. [Google Scholar] [CrossRef] [Scilit]
- Geurs, K.; van Wee, B. Backcasting as a tool for sustainable transport policy making: The environmentatlly sustainable transport study in the Netherlands. Eur. J. Transp. Infrastruct. Res. 2004, 4, 47–69. [Google Scholar]
- Vägverket. Nollvisionen—En Idé Om Ett Vägtransportsystem Utan Hälsoförluster; Vägverket: Borlänge, Sweden, 1996.
- Anderson, R.W.G.; Mclean, A.J.; Farmer, M.J.B.; Lee, B.H.; Brooks, C.G. Vehicle travel speeds and the incidence of fatal pedestrian crashes. Accid. Anal. Prev. 1997, 29, 667–674. [Google Scholar] [CrossRef] [Scilit]
- Tingvall, C.; Haworth, N. Vision Zero—An ethical approach to safety and mobility. In Proceedings of the 6th ITE International Conferene Road Safety & Traffic Enforcement: Beyond 2000, Melbourne, Australia, 6–7 September 1999. [Google Scholar]
- Welle, B.; Sharpin, A.B.; Adriazola-Steil, C.; Job, S.; Shotten, M.; Bose, D.; Bhatt, A.; Alveano, S.; Obelheiro, M.; Imamoglu, T. Safe and Sustainable: A Vision and Guidance for Zero Road Deaths; World Resources Institute & Global Road Safety Facility: Washington, DC, USA, 2018. [Google Scholar]
- Rosen, E.; Sander, U. Pedestrian fatality risk as a function of car impact speed. Accid. Anal. Prev. 2009, 41, 536–542. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Jurewicz, C.; Sobhani, A.; Woolley, J.; Dutschke, J.; Corben, B. Exploration of vehicle impact speed—Injury severity relationships for application in safer road design. Transp. Res. Procedia 2016, 14, 424–425. [Google Scholar] [CrossRef] [Scilit]
- Doecke, S.; Dutschke, J.; Baldock, M.; Kloeden, C. Travel speed and the risk of serious injury in vehicle crashes. Accid. Anal. Prev. 2021, 161, 106359. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- State Government of Victoria. Movement and Place in Victoria; Department of Transport: Melbourne, VIC, Australia, 2019.
- European Commission. Road Traffic Accident Statistics; 2015; Available online: https://unece.org/DAM/trans/doc/2015/wp6/_Maria_Teresa_Sanz_Villegas__UNECE_17_June_2015.pdf (accessed on 23 December 2021).
- Tingvall, C.; Ifver, J.; Krafft, M.; Kullgren, A.; Lie, A.; Rizzi, M.; Sternlund, S.; Stigson, H.; Strandroth, J. The Consequences of Adopting a MAIS 3 Injury Target for Road Safety in the EU, a Comparison with Targets Based on Fatalities and Long-term Consequences. In Proceedings of the International Research Council on the Biomechanics of Injury, Gothenburg, Sweden, 11–13 September 2013. [Google Scholar]
- Malm, S.; Krafft, M.; Kullgren, A.; Ydenius, A.; Tingvall, C. Risk of permanent medical impairment (RPMI) in road traffic accidents. Annu. Proc. Assoc. Adv. Automot. Med. 2008, 52, 93–100. [Google Scholar]
- European Commission; Directorate-General for Internal Market, Industry, Entrepreneurship; SMEs; McCarthy, M.; Seidl, M.; Hunt, R.; Mohan, S.; Hynd, D.; O’Connell, S.; Martin, P.; et al. In Depth Cost-Effectiveness Analysis of the Identified Measures and Features regarding the Way forward for EU Vehicle Safety: Final Report; Publications Office of the European Union: Luxembourg, 2017.
- Eugensson, A.; Ivarsson, J.; Lie, A.; Tingvall, C. Cars are driven on roads, joint visions and modern technologies stress the need for cooperation. In Proceedings of the 22nd Enhanced Safety of Vehicles Conference, Washington, DC, USA, 13–16 June 2011. [Google Scholar]
- Rosen, E. Pedestrian Risk for MAIS3+F Injury—A Work Description; Autoliv: Vårgårda, Sweden, 2010. [Google Scholar]
- Ding, C.; Rizzi, M.; Strandroth, J.; Sander, U.; Lubbe, N. Motorcyclist injury risk as a function of real-life crash speed and other contributing factors. Accid. Anal. Prev. 2019, 123, 374–386. [Google Scholar] [CrossRef] [Scilit]
- Wu, A.; Jeppsson, H.; Lubbe, N. Development of Injury Risk Curves as the Basis for Safe System Speed Limit; Autoliv: Vårgårda, Sweden, 2021. [Google Scholar]
- Kullgren, A. Dose-response models and edr data for assessment of injury risk and effectiveness of safety systems. In Proceedings of the IRCOBI, Bern, Switzerland, 17–19 September 2008. [Google Scholar]
- Gabauer, D.J.; Gabler, H.C. Comparison of delta-v and occupant impact velocity crash severity metrics using event data recorders. Annu. Proc. Assoc. Adv. Automot. Med. 2006, 50, 57–71. [Google Scholar]
- Krafft, M.; Kullgren, A.; Malm, S.; Ydenius, A. Influence of Crash Severity on Various Whiplash Injury Symptoms: A Study Based on Real-Life Rear-End Crashes with Recorded Crash Pulses. In Proceedings of the Enhanced Safety of Vehicles, Washington, DC, USA, 6–9 June 2005. [Google Scholar]
- Australasian New Car Assessment Program. ANCAP Test Protoco. Oblique Pole Side Impact v7.0.2; 2018; Available online: https://s3.amazonaws.com/cdn.ancap.com.au/app/public/assets/bb1f6cd32724457956604d3e102cf7ad2913116f/original.pdf?1501468828 (accessed on 23 December 2021).
- European New Car Assessment Program. Euro NCAP Assessment Protocol—Vulnerable Road User Protection. Version 10.0.3; 2019; Available online: https://cdn.euroncap.com/media/58230/euro-ncap-assessment-protocol-vru-v1003.pdf (accessed on 23 December 2021).
- Global Designing Cities Initiative. Global Street Design Guide; Global Designing Cities Initiative: New York, NY, USA, 2017. [Google Scholar]
- Strandroth, J. Identifying the Potential of Combined Road Safety Interventions—A Method to Evaluate Future Effects of Integrated Road and Vehicle Safety Technologies; Chalmers University of Technology: Gothenburg, Sweden, 2015. [Google Scholar]
- World Health Organisation. Voluntary Global Performance Targets for Road Safety Risk Factors; WHO: Geneva, Switzerland, 2018. [Google Scholar]
- World Health Organisation. Global Status Report on Road Safety 2016; WHO: Geneva, Switzerland, 2018. [Google Scholar]
- Highway Loss Data Institute. Predicted Availability of Safety Features on Registered Vehicles—An Update; Highway Loss Data Institute: Arlington, TX, USA, 2014. [Google Scholar]
- Candappa, N.; D’Elia, A.; Corben, B.; Newstead, S. Wire rope barrier effectiveness on Victorian roads. In Proceedings of the Australasian Road Safety Research, Policing and Education Conference, Perth, Western, Australia, 6–9 November 2011. [Google Scholar]
- Alluri, P.; Haleem, K.; Gan, A.; Mauthner, J. Safety performance evaluation of cable median barriers on freeways in Florida. Traffic Inj. Prev. 2016, 17, 544–551. [Google Scholar] [CrossRef] [Scilit]
- Thomas, B.; DeRobertis, M. The safety of urban cycle tracks: A review of the literature. Accid. Anal. Prev. 2013, 52, 219–227. [Google Scholar] [CrossRef] [Scilit]
- Silla, A.; Luoma, J. Effect of three countermeasures against the illegal crossing of railway tracks. Accid. Anal. Prev. 2010, 43, 1089–1094. [Google Scholar] [CrossRef] [Scilit]
- Gan, A.; Shen, J.; Rodriguez, A. Update of Florida Crash Reduction Factors and Countermeasures to Improve the Development of District Safety Improvement Projects: Final Report; Lehman Center for Transportation Research Florida International University: Miami, FL, USA, 2005. [Google Scholar]
- He, Q.; Kamineni, R.; Zhang, Z. Traffic signal control with partial grade separation for oversaturated conditions. Transp. Res. Part C Emerg. Technol. 2016, 71, 267–283. [Google Scholar] [CrossRef] [Scilit]
- Turner, B.; Imberger, K.; Roper, P.; Pyta, V.; McLean, J. Road Safety Engineering Risk Assessement Part 6: Crash Reduction Factors; AP-T151/10; Austroads: Sydney, NSW, Australia, 2010. [Google Scholar]
- Ward, J.; Hall, C.; Robertson, J.; Durdin, P.; Smith, D. Guide to Traffic Management Part 6: Intersections, Interchanges and Crossings; AGTM06-19; Austroads: Sydney, NSW, Australia, 2019. [Google Scholar]
- Zegeer, C.; Hummer, J.; Reinfurt, D.; Herf, L.; Hunter, W. Safety Effects of Cross-Section Design for Two Lane Roads, Volume 1, Final Report; Federal Highway Adminstration: Washington, DC, USA, 1987.
- Martino, A.; Sitran, A.; Rosa, C. Technical Development and Deployment of Alcohol Interlocks in Road Safety Policy; European Union: Brussels, Belgium, 2014. [Google Scholar]
- Ward, G.M.; Vanlaar, W.G.; Mainegra Hing, M.; Robertson, R.D. An evaluation of Nova Scotia’s alcohol ignition interlock program. Accid. Anal. Prev. 2017, 100, 44–52. [Google Scholar]
- Chajmowicz, H.; Saade, J.; Cuny, S. Prospective assessment of the effectiveness of autonomous emergency braking in car-to-cyclist accidents in France. Traffic Inj. Prev. 2019, 20, S20–S25. [Google Scholar] [CrossRef] [Scilit]
- Fildes, B.; Keall, M.; Bos, N.; Lie, A.; Page, Y.; Pastor, C.; Pennisi, L.; Rizzi, M.; Thomas, P.; Tingvall, C. Effectiveness of low speed autonomous emergency braking in real-world rear-end crashes. Accid. Anal. Prev. 2015, 81, 24–29. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Cicchino, J.B. Effectiveness of forward Collision Warning Systems with and without Autonomous Emergency Braking in Reducing Police-Reported Crash Rates; Insurance Institute for Highway Safety: Arlington, TX, USA, 2016. [Google Scholar]
- Seidl, M.; Hynd, D.; McCarthy, M.; Martin, P.; Hunt, R.; Mohan, S.; Krishnamurthy, V.; O’Connell, S. In Depth Cost-Effectiveness Analysis of the Identified Measures and Features regarding the Way forward for EU Vehicle Safety; Transport Research Laboratory: Berkshire, UK, 2017. [Google Scholar]
- Strandroth, J.; Rizzi, M.; Kullgren, A.; Tingvall, C. Head-on collisions between passenger cars and heavy goods vehicles: Injury risk functions and benefits of autonomous emergency braking. In Proceedings of the International Research Council on the Biomechanics of Injury, Dublin, Ireland, 12–14 September 2012. [Google Scholar]
- Sander, U. Opportunities and limitations for intersection collision intervention—A study of real world ‘left turn across path’ accidents. Accid. Anal. Prev. 2017, 99, 342–355. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Isaksson-Hellman, I.; Lindman, M. Evaluation of rear-end collision avoidance technologies based on real world crash data. In Proceedings of the 3rd International Symposium o Future Active Safety Technology Towards Zero Traffic Accidents, Gothenburg, Sweden, 9–11 September 2015. [Google Scholar]
- Rosen, E.; Kallhammer, J.E.; Eriksson, D.; Nentwich, M.; Fredriksson, R.; Smith, K. Pedestrian injury mitigation by autonomous braking. Accid. Anal. Prev. 2010, 42, 1949–1957. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Fredriksson, R.; Rosen, E. Head injury reduction potential of integrated pedestrian protection systems based on accident and experimental data—Benefit of combining passive and active systems. In Proceedings of the IRCOBI Conference, Berlin, Germany, 10–12 September 2014. [Google Scholar]
- Cicchino, J.B. Real-World Effects of General Motors Rear Automatic Braking, Rear Vision Camera, and Rear Parking Assist Systems; Insurance Institute for Highway Safety: Arlington, TX, USA, 2018. [Google Scholar]
- Ponte, G.; Ryan, G.A.; Anderson, R.W. An estimate of the effectiveness of an in-vehicle automatic collision notification system in reducing road crash fatalities in South Australia. Traffic Inj. Prev. 2016, 17, 258–263. [Google Scholar] [CrossRef] [Scilit]
- Carsten, O.; Lai, F.; Chorlton, K.; Goodmam, P.; Carslaw, D.; Hess, S. Speed Limit Adherence and Its Effect on Road Safety and Climate Change—Final Report; University of Leeds: Leeds, UK, 2008. [Google Scholar]
- Lai, F.; Carsten, O.; Tate, F. How much benefit does Intelligent Speed Adaptation deliver: An analysis of its potential contribution to safety and environment. Accid. Anal. Prev. 2012, 48, 63–72. [Google Scholar] [CrossRef] [Scilit]
- Kidd, D.G.; Singer, J.; Huey, R.; Kerfoot, L. The effect of a gearshift interlock on seat belt use by drivers who do not always use a belt and its acceptance among those who do. J. Saf. Res. 2018, 65, 39–51. [Google Scholar] [CrossRef] [Scilit]
- Rechnitzer, G. Truck Involved Crash Study: Fatal and Injury Crashes of Cars and Other Road Users with the Front and Sides of Heavy Vehicles; 35; Monash University Accident Research Centre: Clayton, Australia, 1993. [Google Scholar]
- Smith, T.L.; Grover, C.; Gibson, T.; Donaldson, W.; Knight, I. Development of Test Procedures, Limit Values, Costs and Benefits for Proposals to Improve the Performance of Rear Underrun Protection for Trucks; TRL Limited: Berkshire, UK, 2008. [Google Scholar]
- Robinson, T.; Cuerden, R. Safer Lorries in London: Identifying the Casualties Associated with Side Guard Rails and Mirror Exemptions; Transport Research Laboratory: Berkshire, UK, 2014. [Google Scholar]
- Newstead, S.; Delaney, A.; Watson, L.; Cameron, M. A Model for Considering the ‘Total Safety’ of the Light Paseenger Vehicle Fleet; Monash University Accident Research Centre: Clayton, Australia, 2004. [Google Scholar]
- Paine, M.; Paine, D.; Case, M.; Haley, J.; Newland, C.; Worden, S. Trends with ANCAP safety ratings and real-world crash performnce for vehicle models in Australia. In Proceedings of the 23rd International Technical Conference on the Enhanced Safety of Vehicles, Seoul, Korea, 27–20 May 2013. [Google Scholar]
- Kullgren, A.; Lie, A.; Tingvall, C. Comparison between Euro NCAP test results and real-world crash data. Traffic Inj. Prev. 2010, 11, 587–593. [Google Scholar] [CrossRef] [Scilit]
- European Commission. Vehicle Categories. Available online: https://ec.europa.eu/growth/sectors/automotive-industry/vehicle-categories_en (accessed on 23 December 2021).
- Pulugurtha, S.S.; Thakur, V. Evaluating the effectiveness of on-street bicycle lane and assessing risk to bicyclists in Charlotte, North Carolina. Accid. Anal. Prev. 2015, 76, 34–41. [Google Scholar] [CrossRef] [Scilit]
- Vaa, T.; Penttinen, M.; Spyropoulou, I. Intelligent transport systems and effects on road traffic accidents: State of the art. IET Intell. Transp. Syst. 2007, 1, 81–88. [Google Scholar] [CrossRef] [Scilit]
- Makwasha, T.; Turner, B. Safety of raised platforms on urban roads. J. Aust. Coll. Road Saf. 2017, 28, 20–27. [Google Scholar]
- VicRoads. VicRoads Supplement to the Austroads Guide to Road Design Part 4A—Signalised and Unsignalised Intersections; VicRoads: Melbourne, VIC, Australia, 2011. [Google Scholar]
- Jurewicz, C. Impact of LATM Treatments on Speed and Safety; Austroads: Sydney, NSW, Australia, 2009. [Google Scholar]
- VicRoads. Supplement to Austroads Guide to Traffic Management Part 8: Local Area Traffic Management (2008); VicRoads: Melbourne, VIC, Australia, 2015. [Google Scholar]
- Daniel, B.D.; Nicholson, A.; Koorey, G. Investigating speed patterns and estimating speed on traffic-calmed streets. In Proceedings of the Institution of Professional Engineers New Zealand (IPENZ) Transportation Conference, Auckland, New Zealand, 27–30 March 2011. [Google Scholar]
- Damen, P.; Brindle, R.; Rueda, M. Guide to Traffic Management Part 8: Local Area Traffic Management; Austroads: Sydney, NSW, Australia, 2016. [Google Scholar]
- Arbogast, H.; Patao, M.; Demeter, N.; Bachman, S.; Devietti, E.; Upperman, J.S.; Burke, R.V. The effectiveness of installing a speed hump in reducing motor vehicle accidents involving pedestrians under the age of 21. J. Transp. Health 2018, 8, 30–34. [Google Scholar] [CrossRef] [Scilit]
- Rothman, L.; Macpherson, A.; Buliung, R.; Macarthur, C.; To, T.; Larsen, K.; Howard, A. Installation of speed humps and pedestrian-motor vehicle collisions in Toronto, Canada: A quasi-experimental study. BMC Public Health 2015, 15, 774. [Google Scholar] [CrossRef] [Scilit]
- Wheeler, A.H.; Taylor, M.C. Changes in Accident Frequency Following the Introduction of Traffic Calming in Villages; 452; Transport Research Laboratory: Berkshire, UK, 2000. [Google Scholar]
- Cicchino, J.B. Effects of blind spot monitoring systems on police-reported lane-change crashes. Traffic Inj. Prev. 2018, 19, 615–622. [Google Scholar] [CrossRef] [Scilit]
- Volvo. Driver Alert System. Available online: https://www.volvocars.com/en-th/support/manuals/v40/2018/driver-support/driver-alert-system/driver-alert-control-dac (accessed on 24 August 2020).
- Wilmink, I.; Janssen, W.; Jonkers, E.; Malone, K.; van Noort, M.; Klunder, G.; Rämer, P.; Sihvola, N.; Kulmala, R.; Schirokoff, A.; et al. e-IMPACT Deliverable 4—Impact Assessment of Intelligent Vehicle Safety Systems; VTT Technical Research Centre of Finland: Espoo, Finland, 2008. [Google Scholar]
- Fitzharris, M.; Liu, S.; Stephens, A.N.; Lenne, M.G. The relative importance of real-time in-cab and external feedback in managing fatigue in real-world commercial transport operations. Traffic Inj. Prev. 2017, 18, S71–S78. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Cicchino, J.B. Effects of lane departure warning on police-reported crash rates. J. Saf. Res. 2018, 66, 61–70. [Google Scholar] [CrossRef] [Scilit]
- Rizzi, M.; Strandroth, J.; Kullgren, A.; Tingvall, C.; Fildes, B. Effectiveness of motorcycle antilock braking systems (ABS) in reducing crashes, the first cross-national study. Traffic Inj. Prev. 2015, 16, 177–183. [Google Scholar] [CrossRef] [Scilit]
- Bijleveld, F.D. Effectiveness of Daytime Motorcycle Headlights in the European Union; SWOV: Den Haag, The Netherlands, 1997. [Google Scholar]
- Paine, M.; Paine, D.; Haley, J.; Cockfield, S. Daytime running lights for motorcycles. In Proceedings of the 19th International Technical Conference on the Enhanced Safety of Vehicles, Washington, DC, USA, 6–9 June 2005. [Google Scholar]
- Keall, M.D.; Fildes, B.; Newstead, S. Real-world evaluation of the effectiveness of reversing camera and parking sensor technologies in preventing backover pedestrian injuries. Accid. Anal. Prev. 2017, 99, 39–43. [Google Scholar] [CrossRef] [Scilit]
- Volvo. Seatbelts. Available online: https://www.volvocars.com/uk/support/manuals/v90/2019-late/safety/seatbelts/door-and-seatbelt-reminder (accessed on 24 August 2020).
- Young, K.L.; Regan, M.A.; Triggs, T.J.; Stephan, K.; Mitsopoulos-Rubens, E.; Tomasevic, N. Field operational test of a seatbelt reminder system: Effects on driver behaviour and acceptance. Transp. Res. Part F Traffic Psychol. Behav. 2008, 11, 434–444. [Google Scholar] [CrossRef] [Scilit]
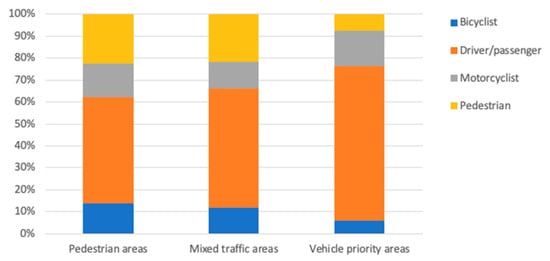
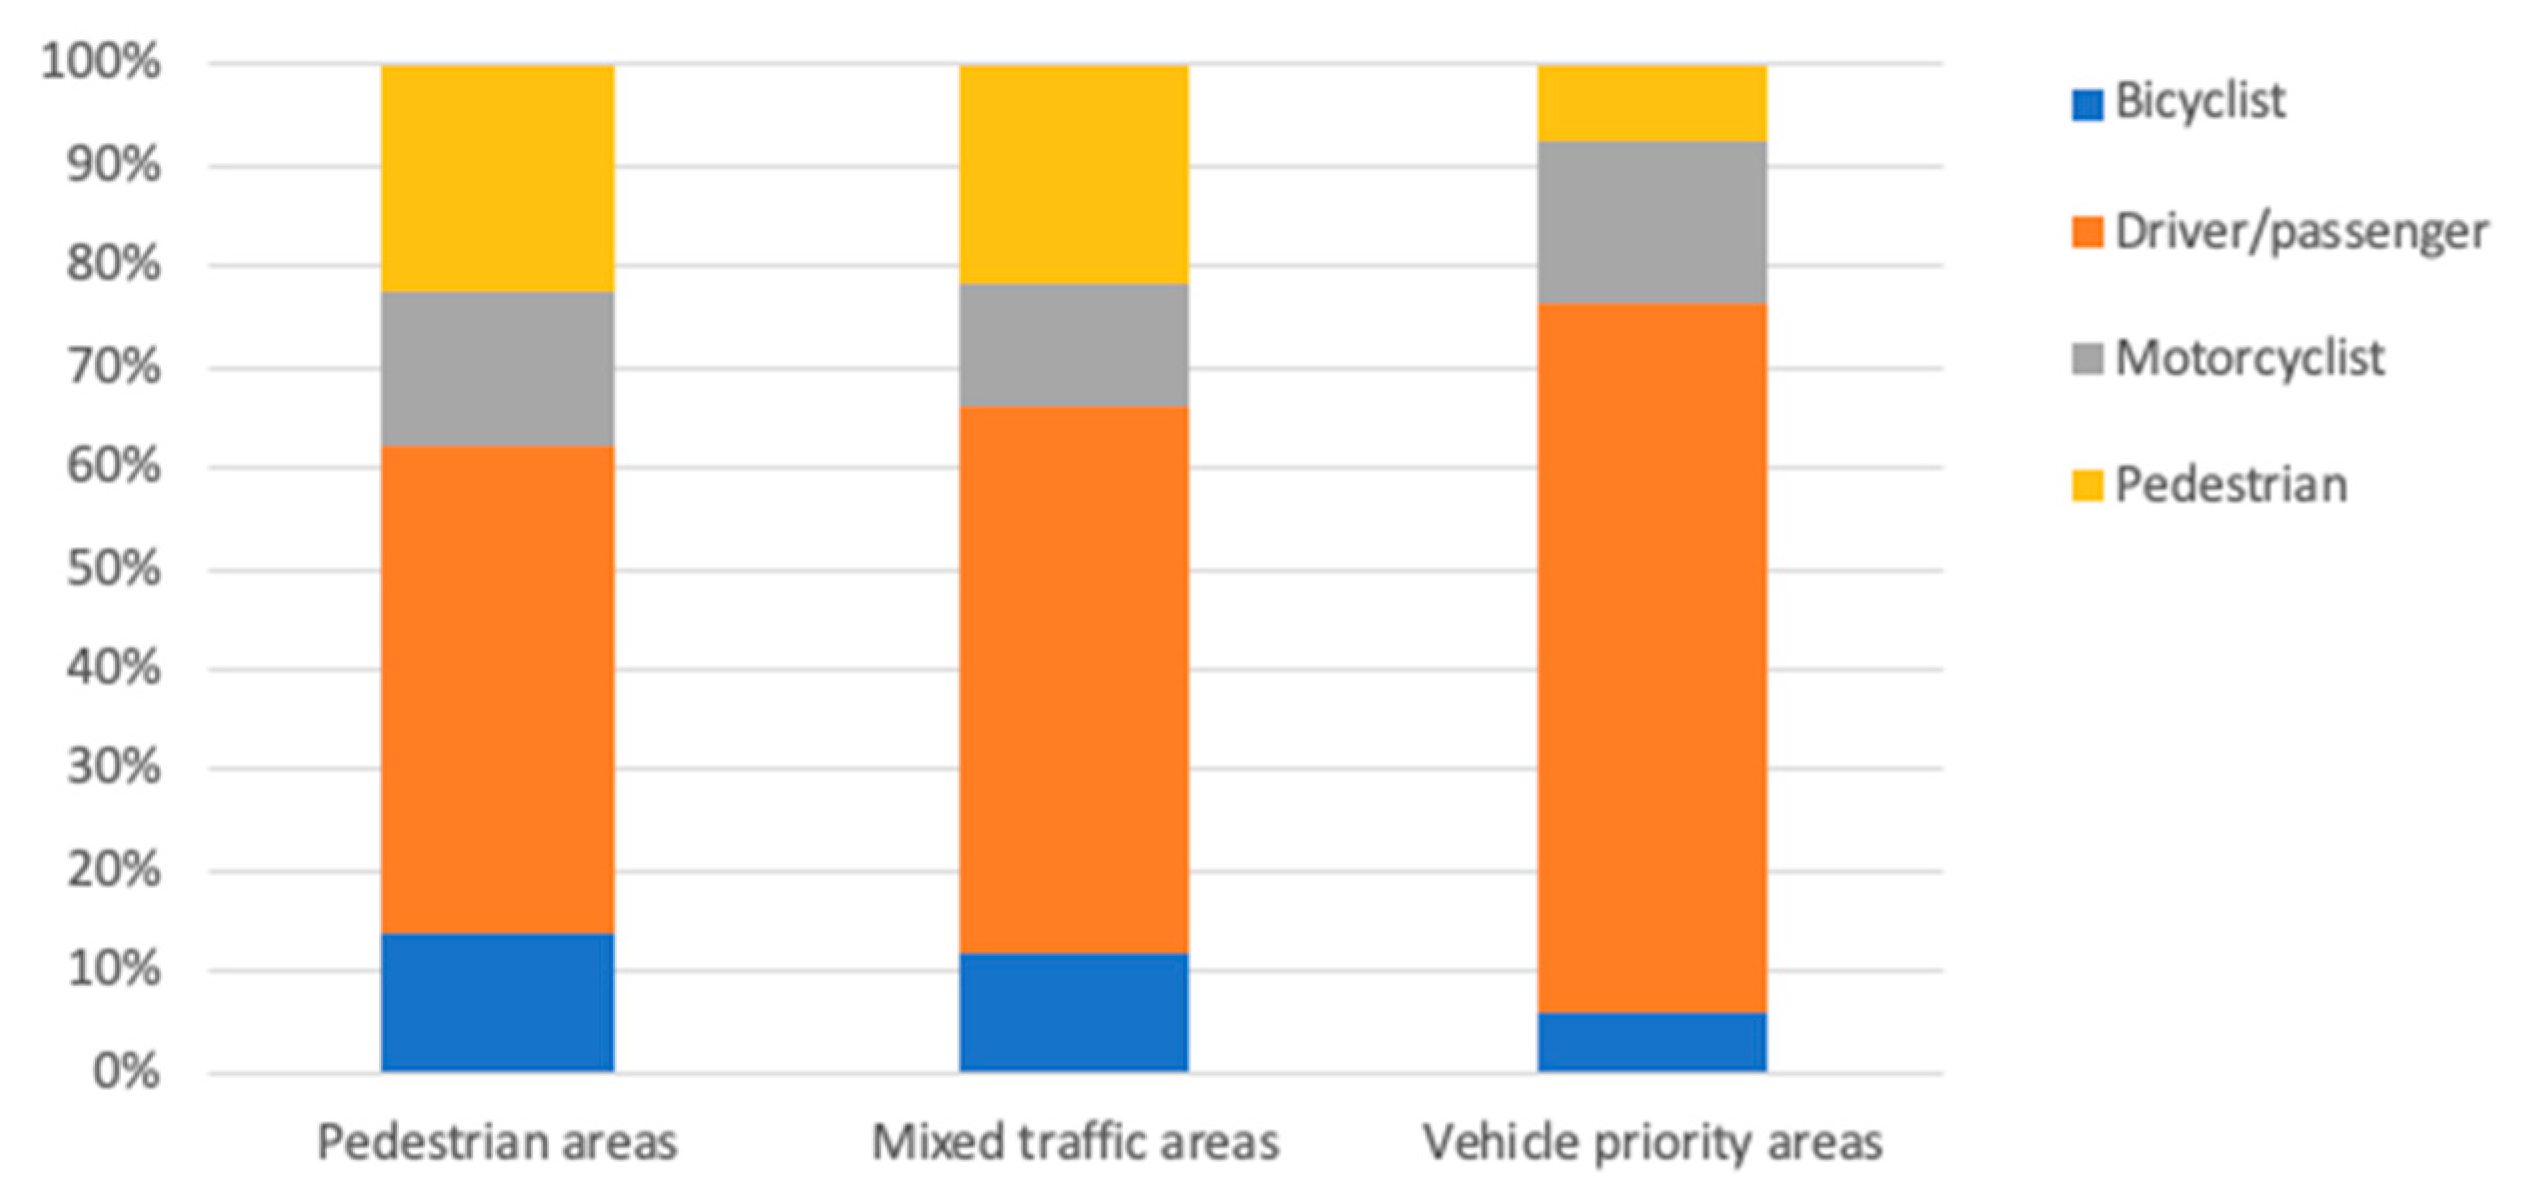
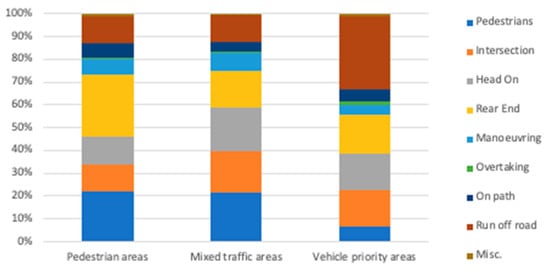
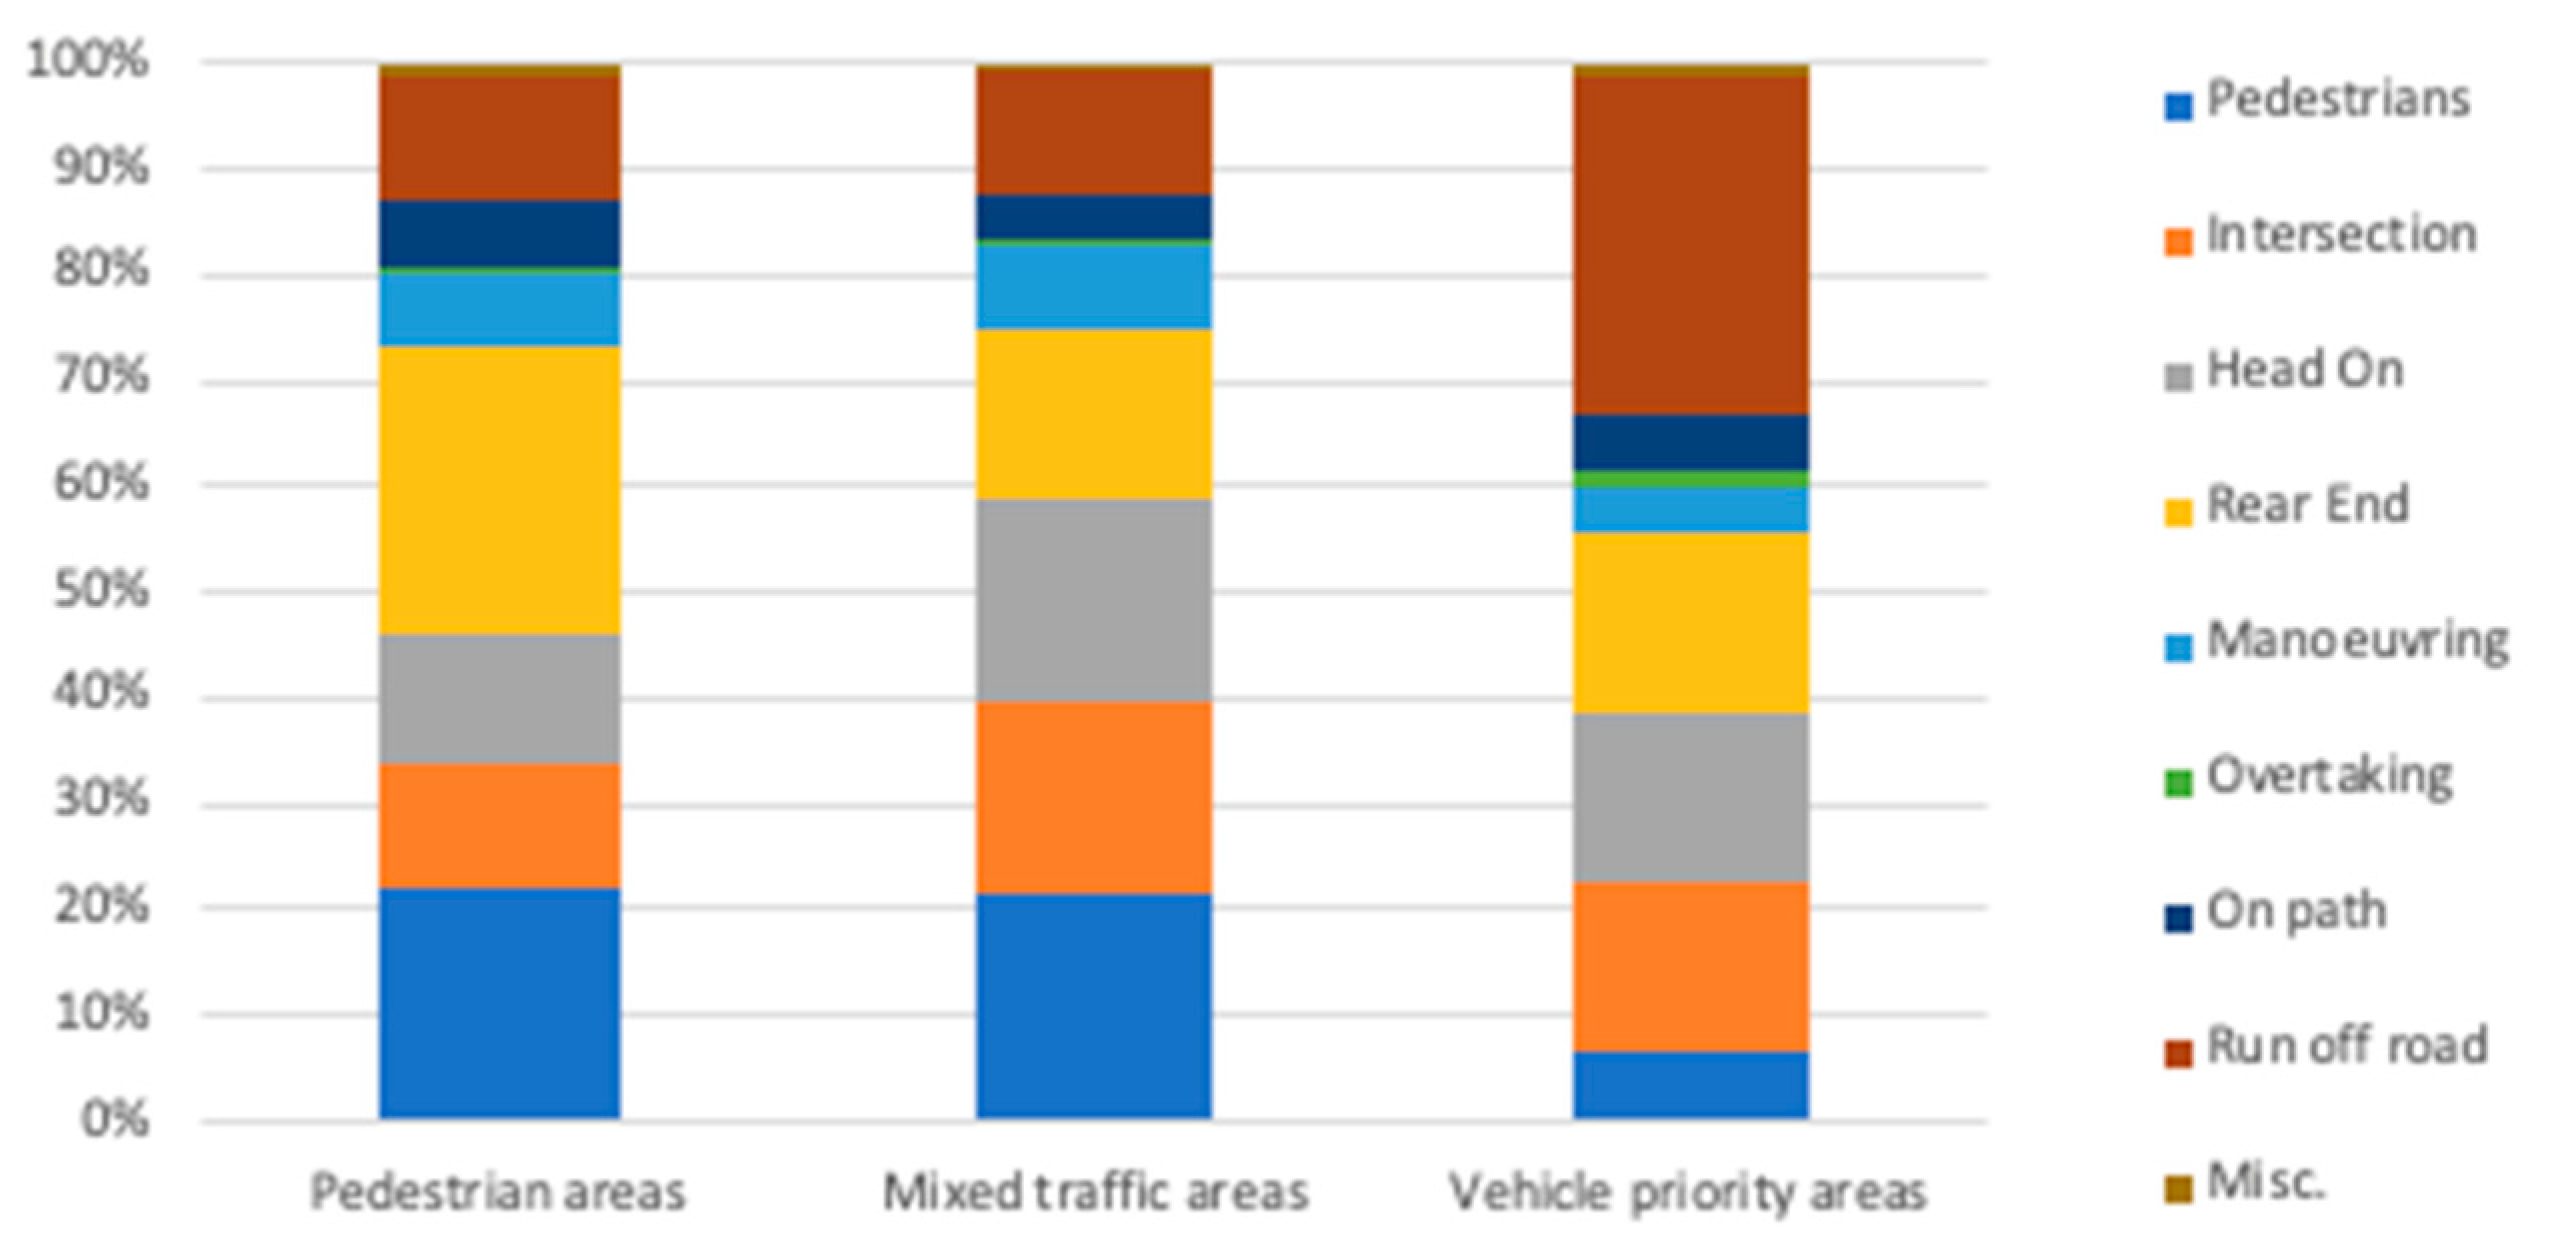


Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).