Article

Learning and Mining Player Motion Profiles in Physically Interactive Robogames


1
Department of Electronics, Information, and Bioengineering, Politecnico di Milano, Piazza Leonardo da Vinci, 32, 20133 Milano, Italy
2
Department of Computer Systems, Federal University of Paraíba (UFPB), João Pessoa, PB 58051-085, Brazil
*
Author to whom correspondence should be addressed.
Future Internet 2018, 10(3), 22; https://doi.org/10.3390/fi10030022
Submission received: 30 October 2017 / Revised: 2 December 2017 / Accepted: 14 December 2017 / Published: 26 February 2018
(This article belongs to the Special Issue Engaging in Interaction with Robots)

Abstract

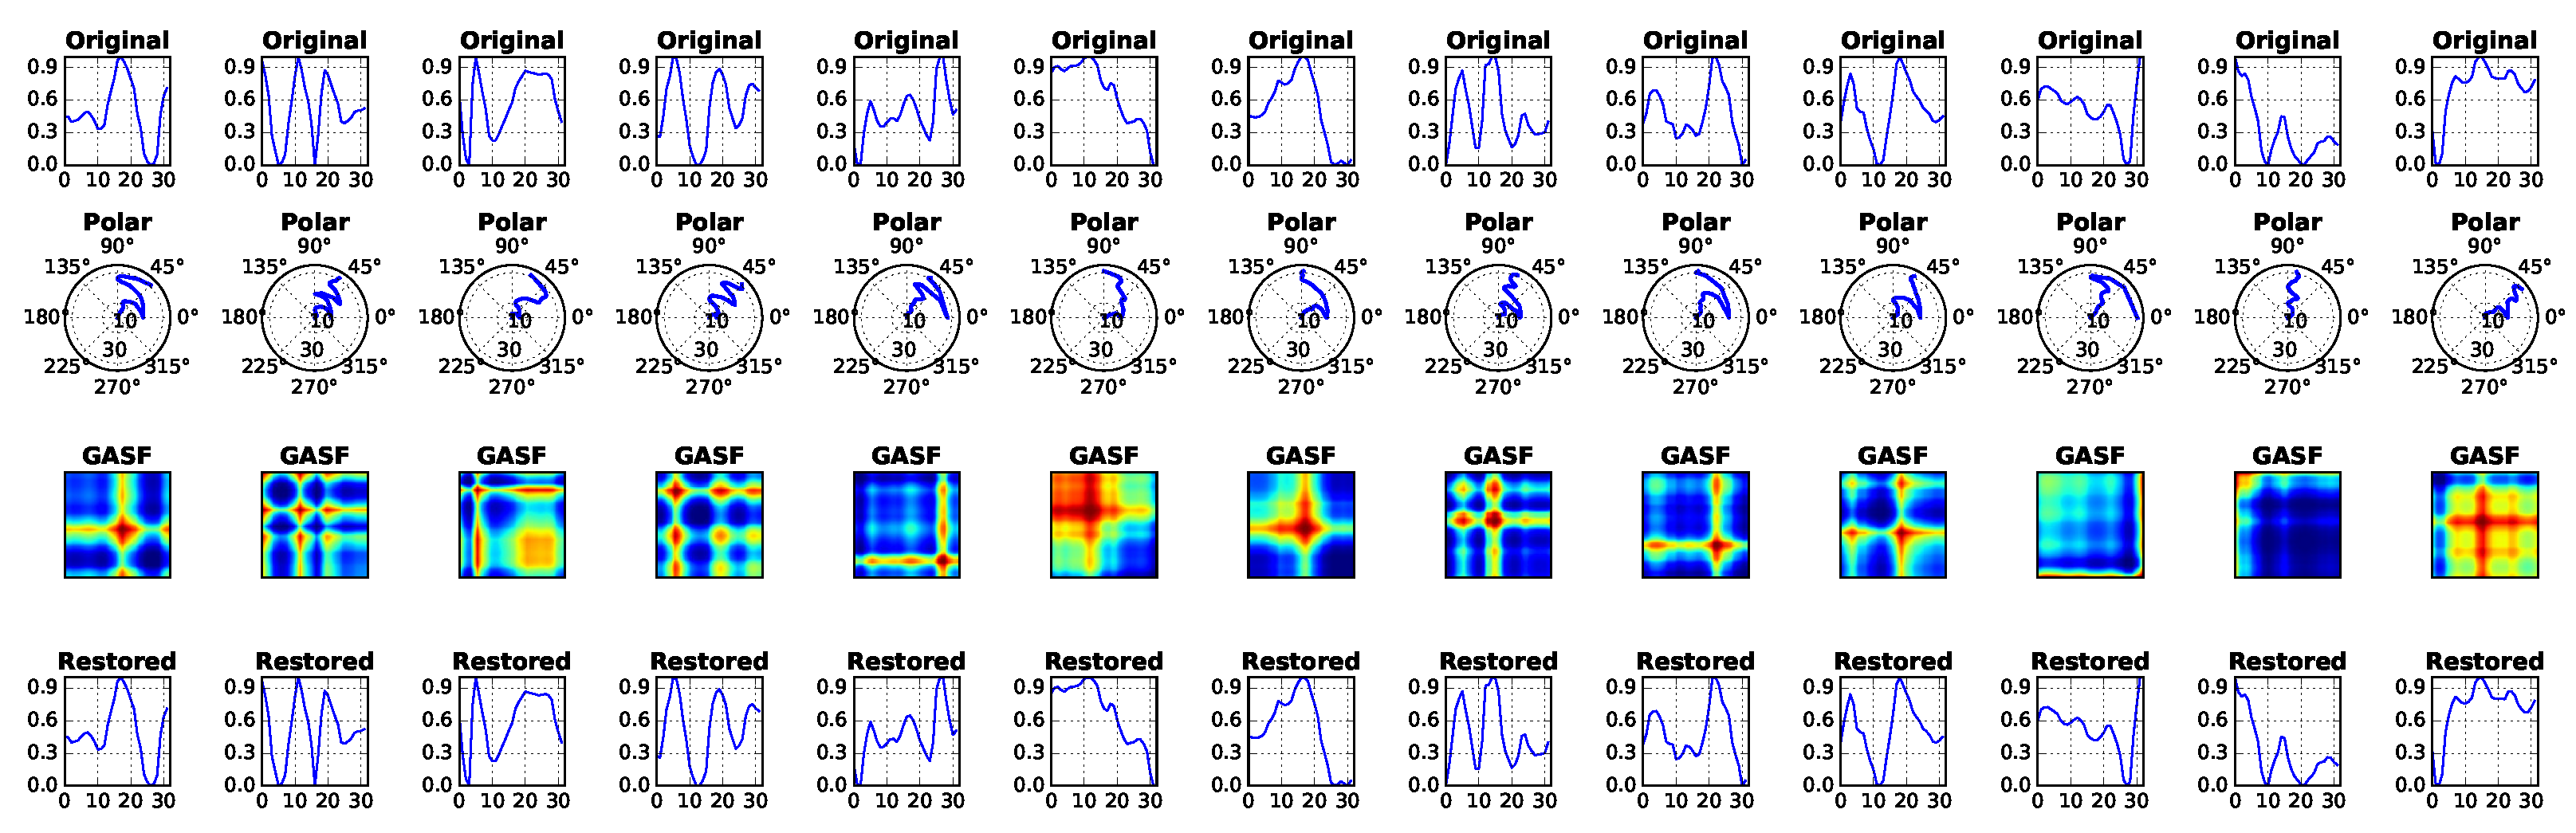
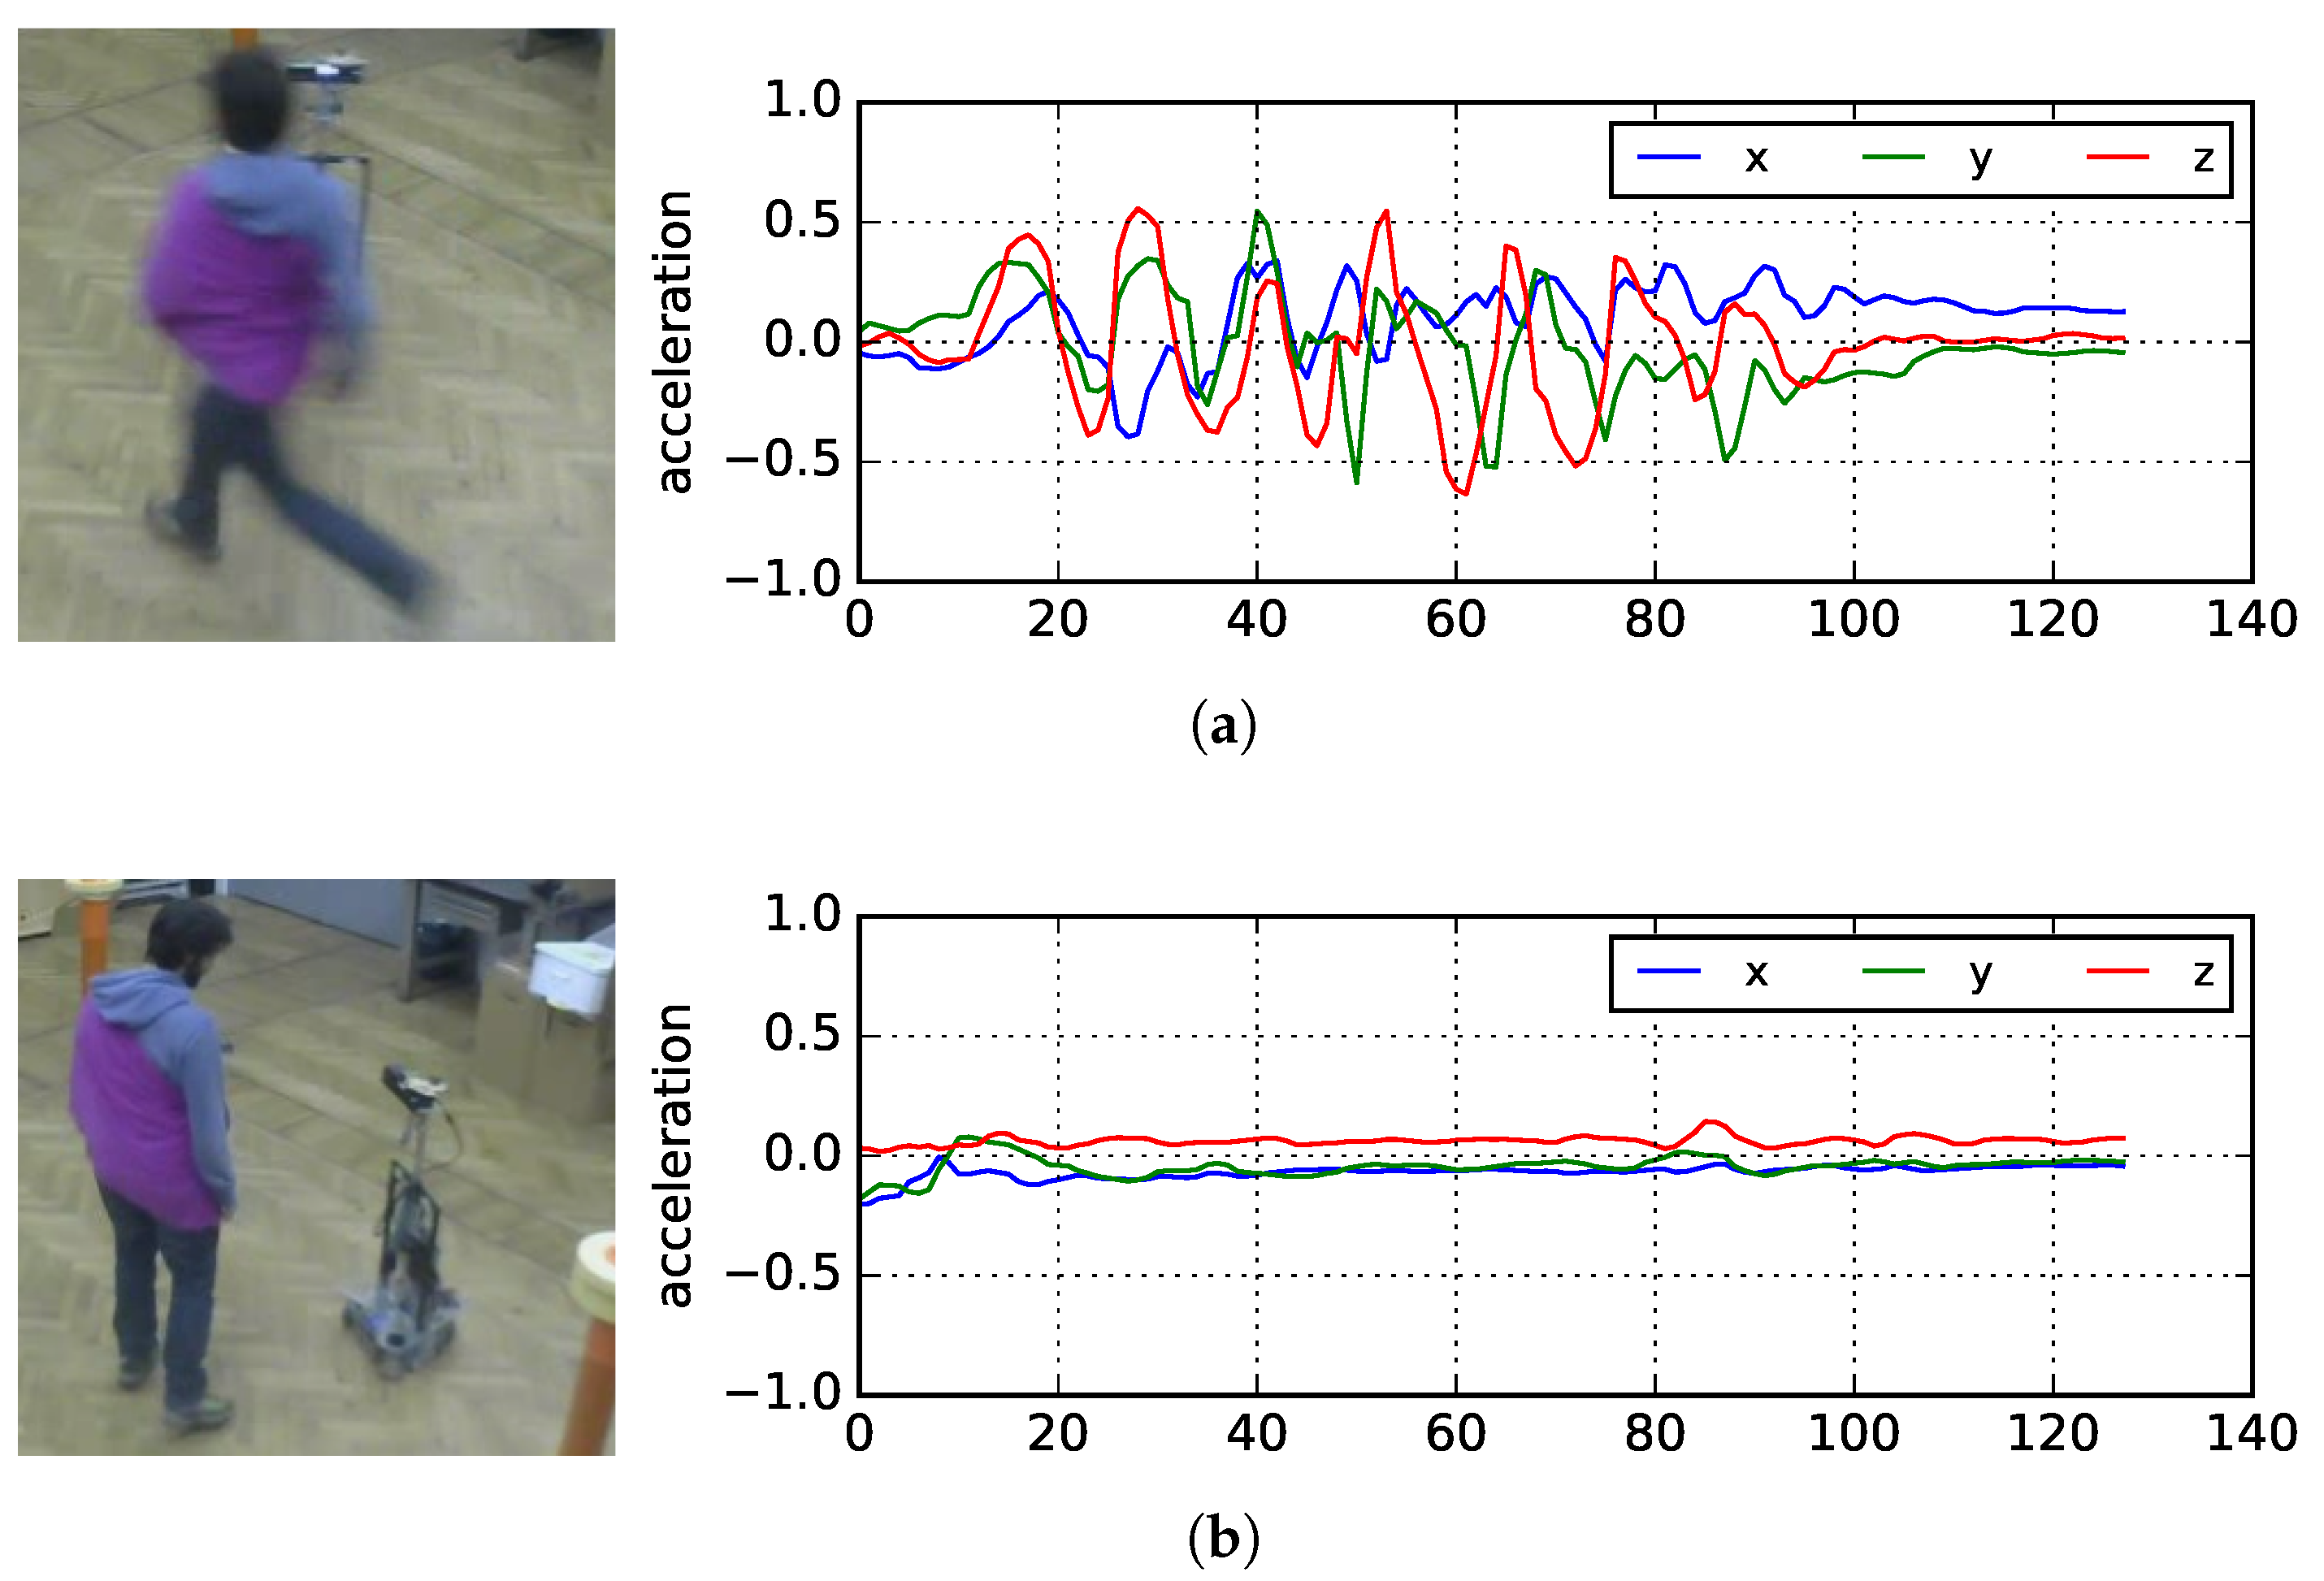
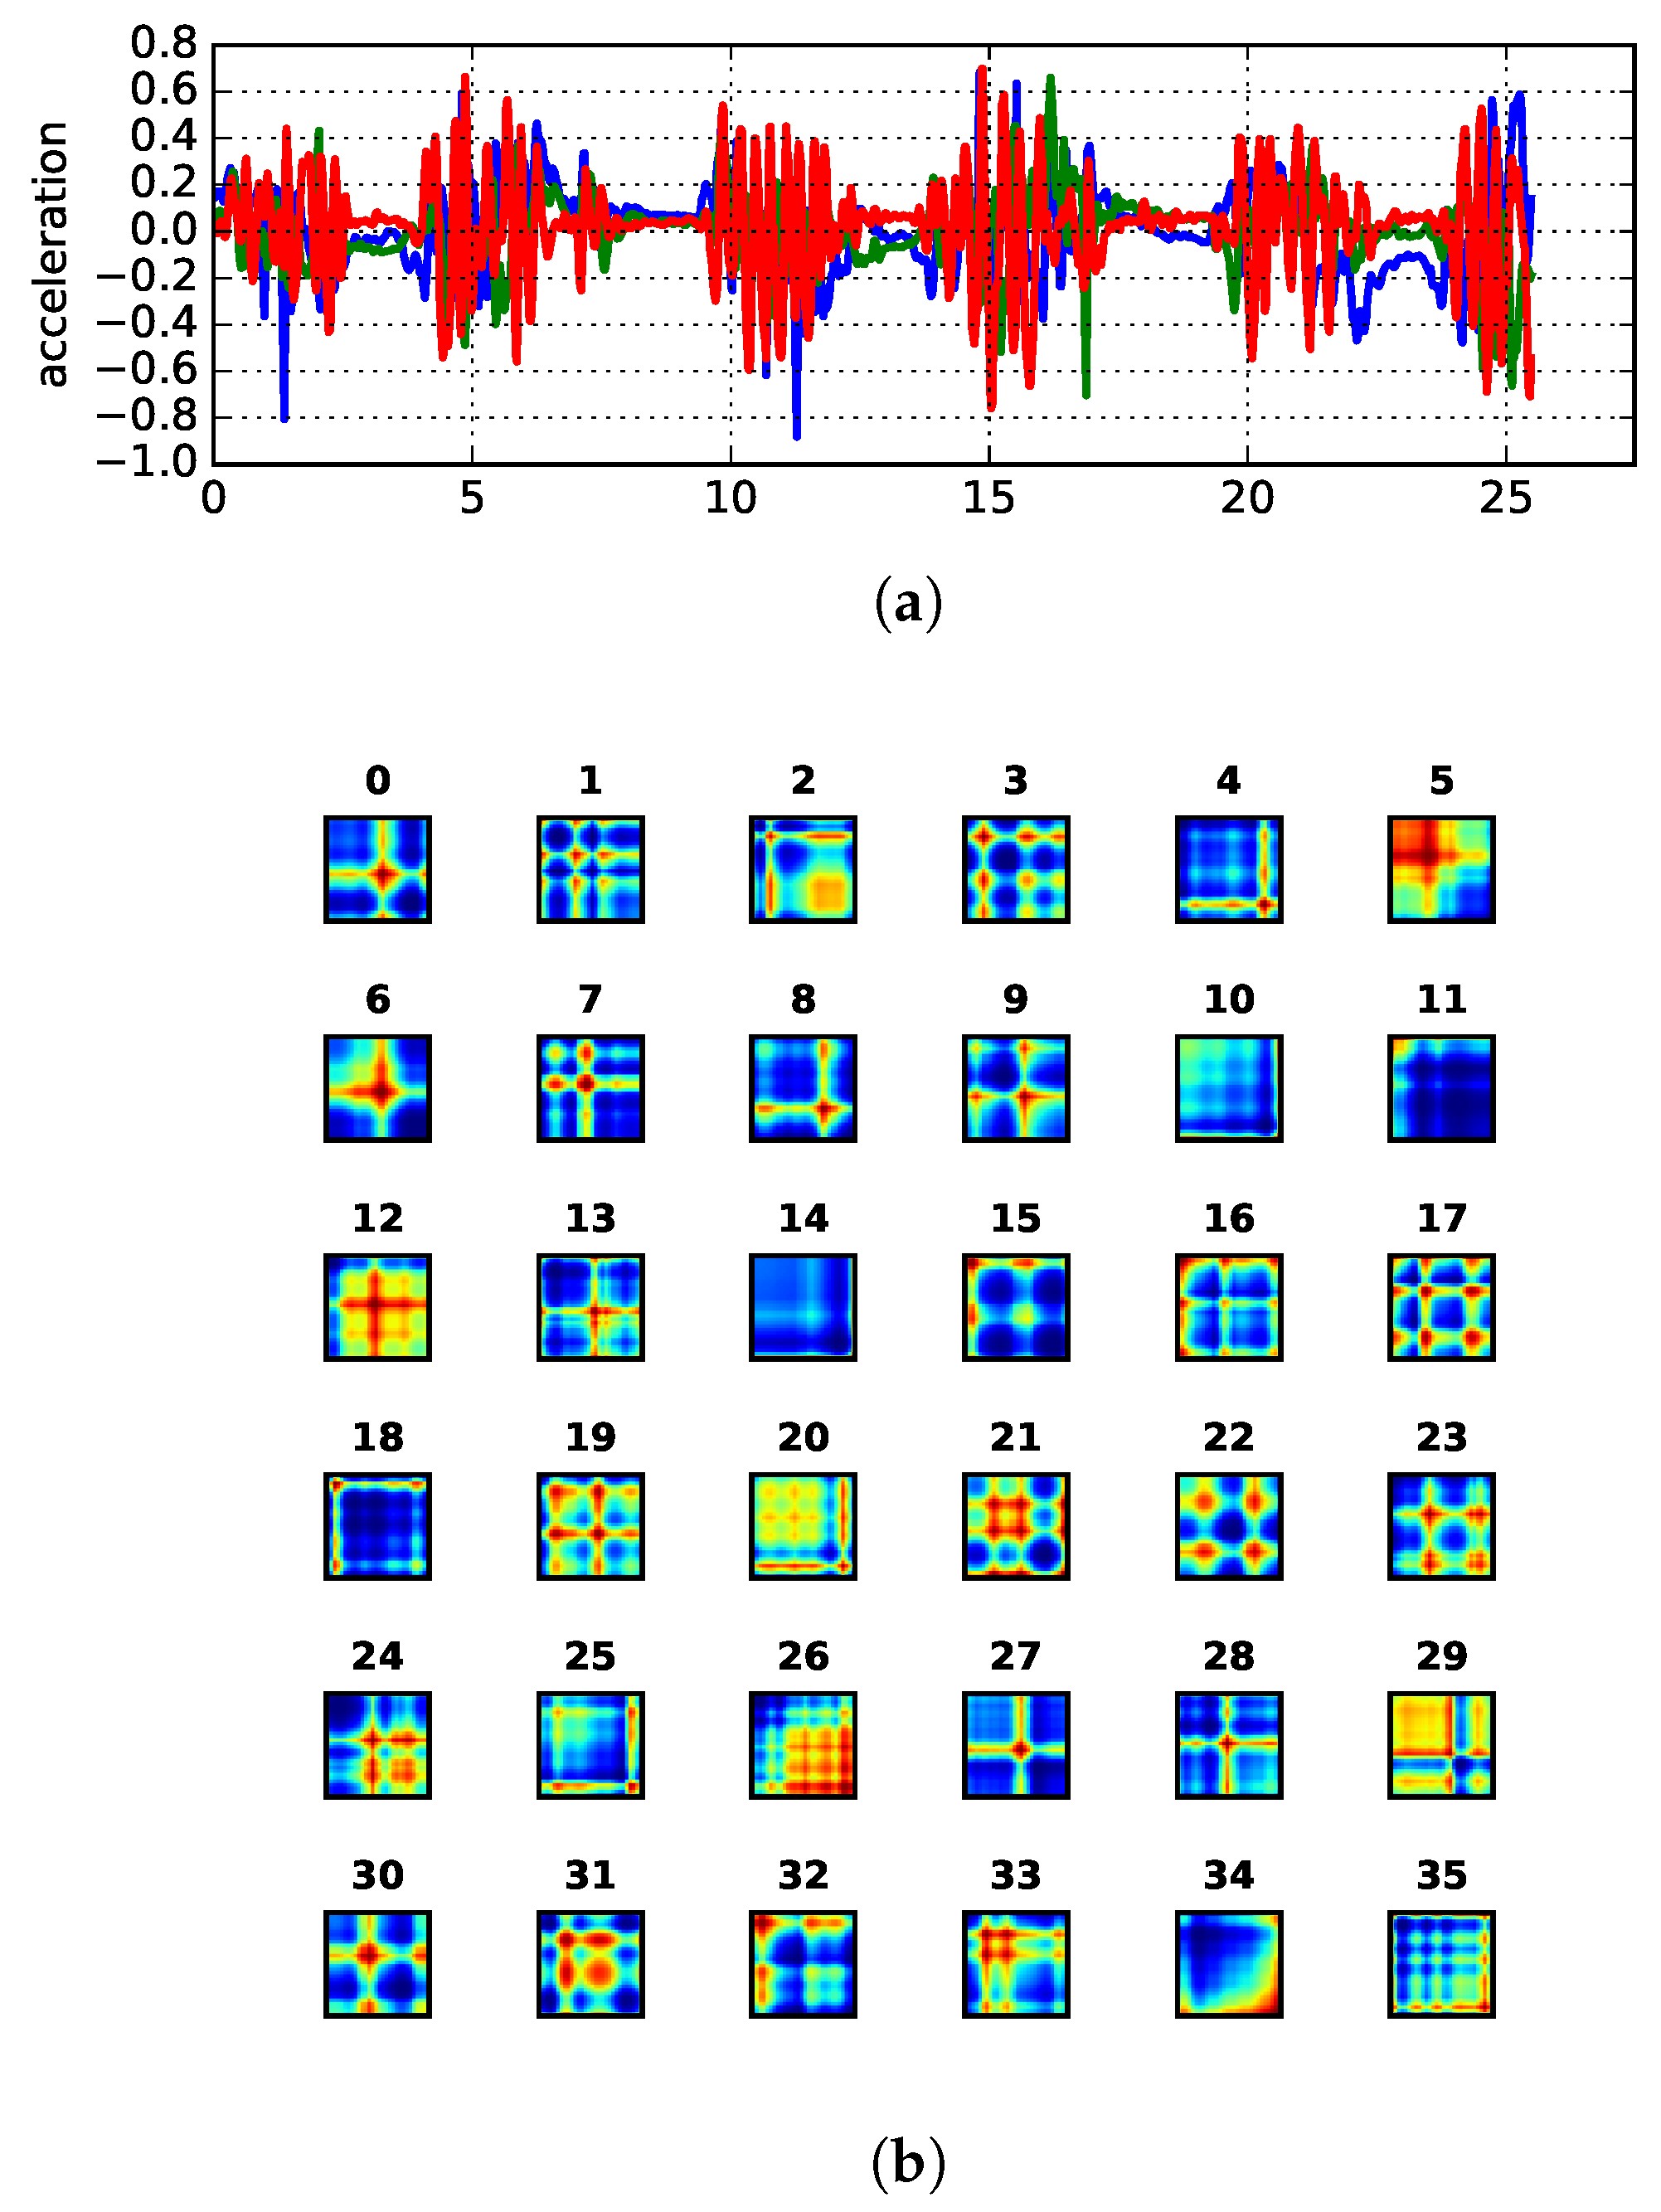
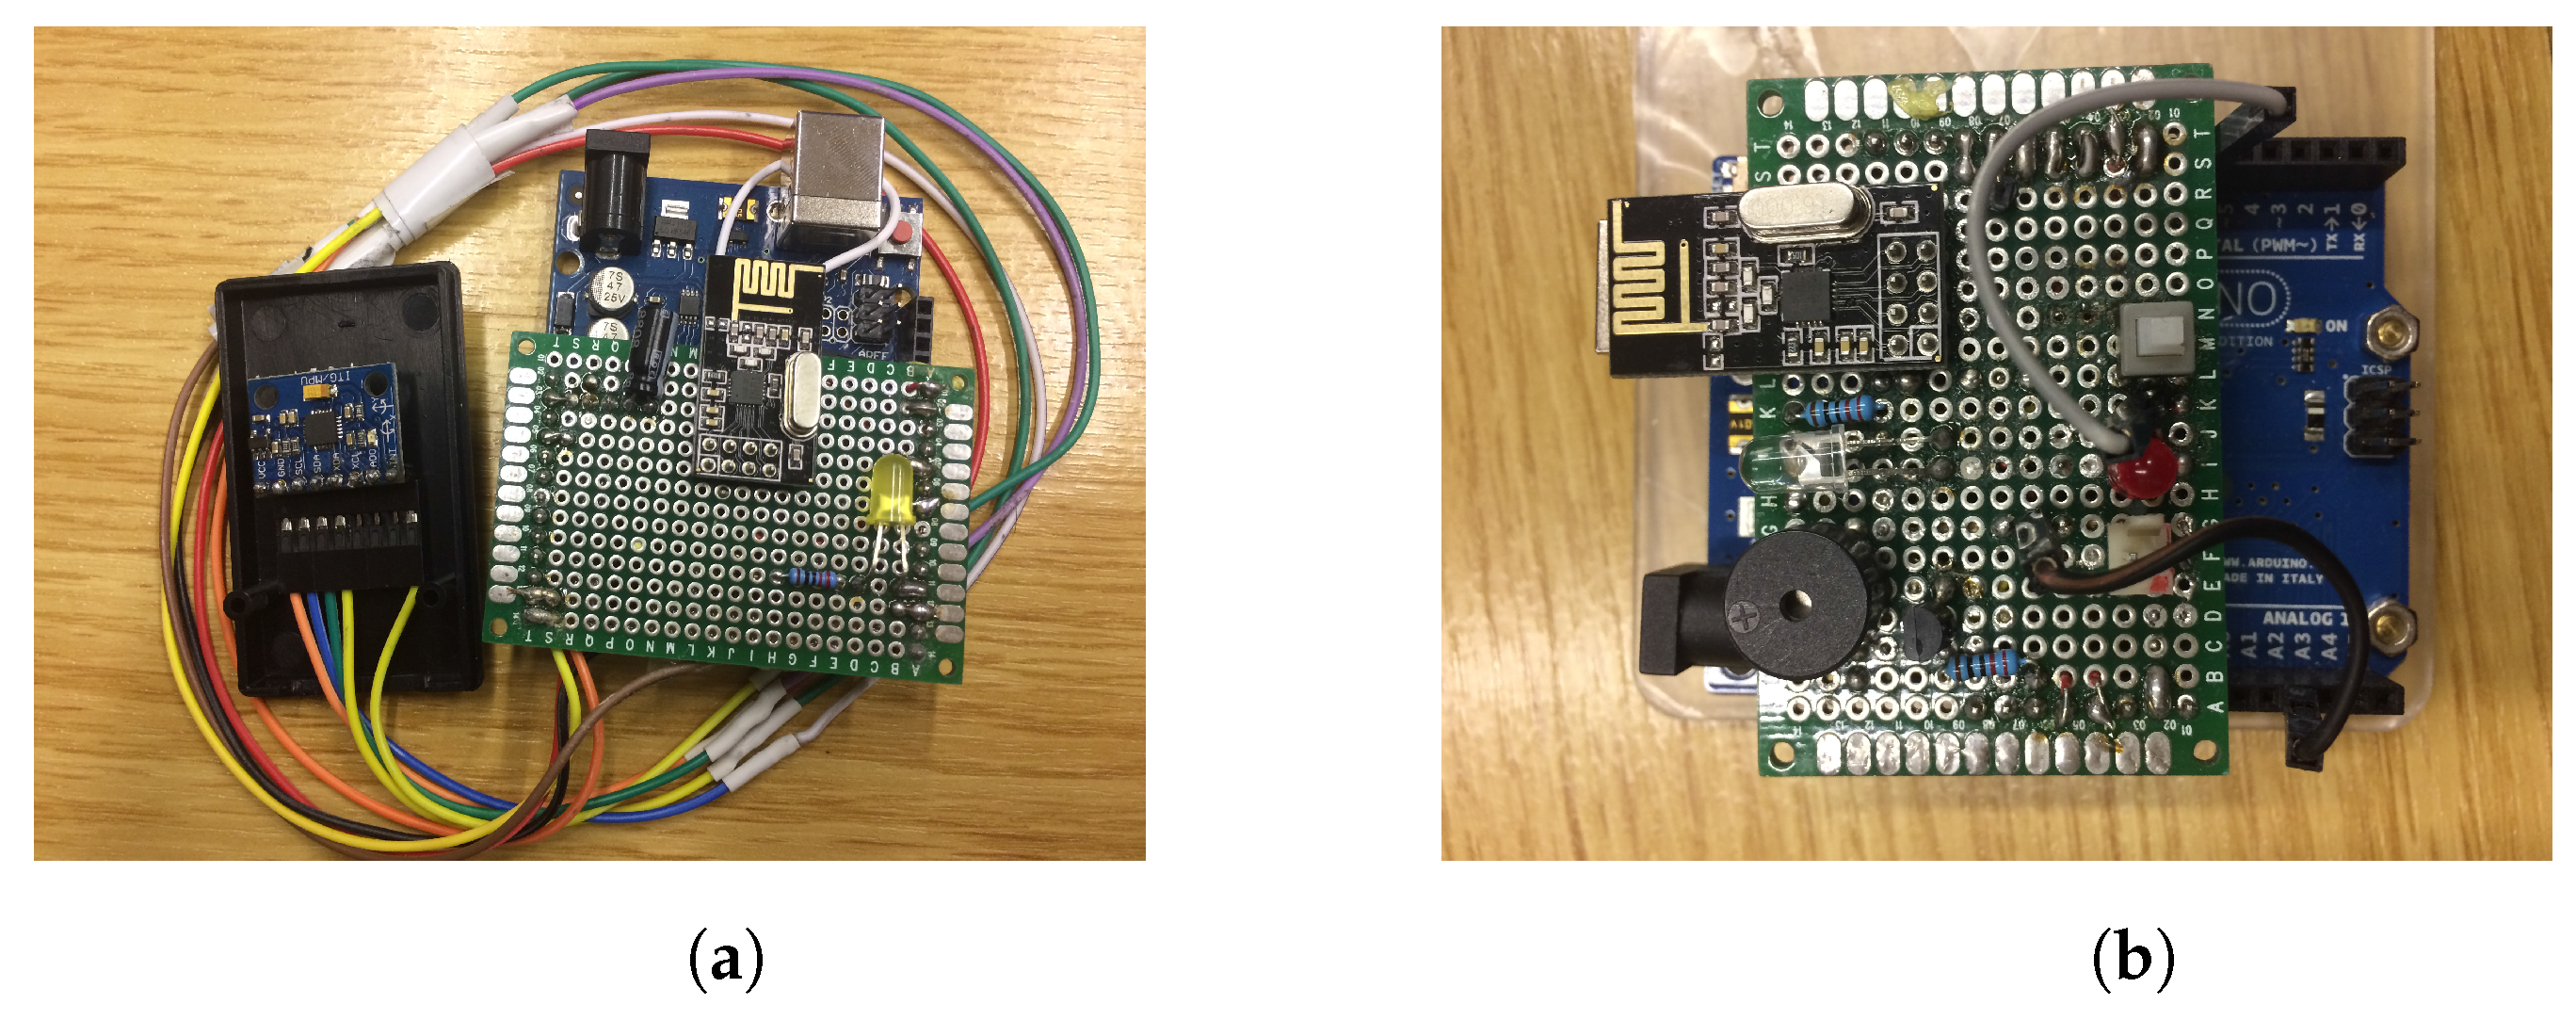
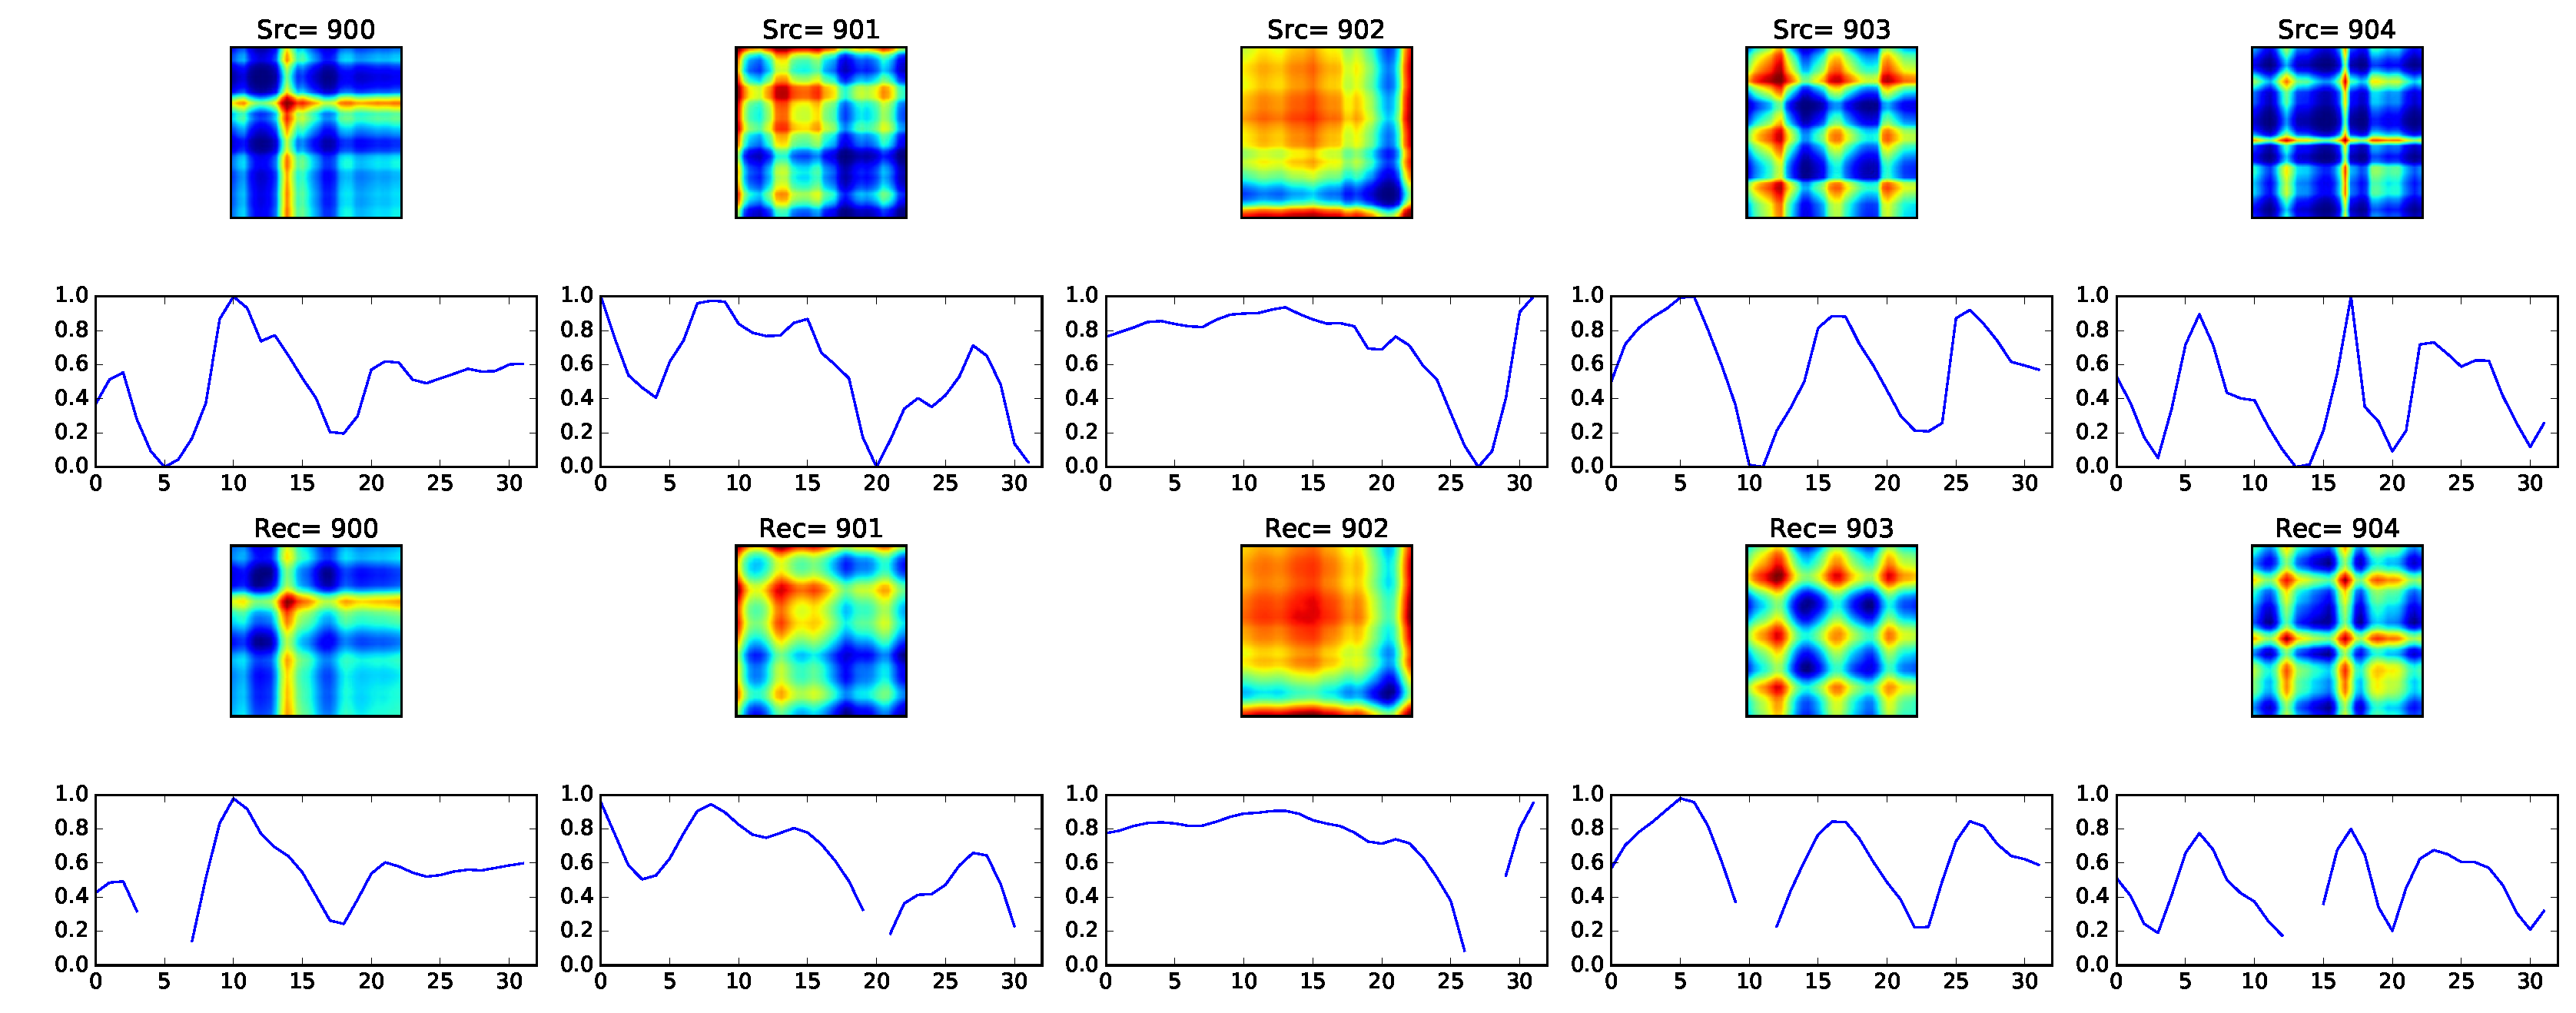
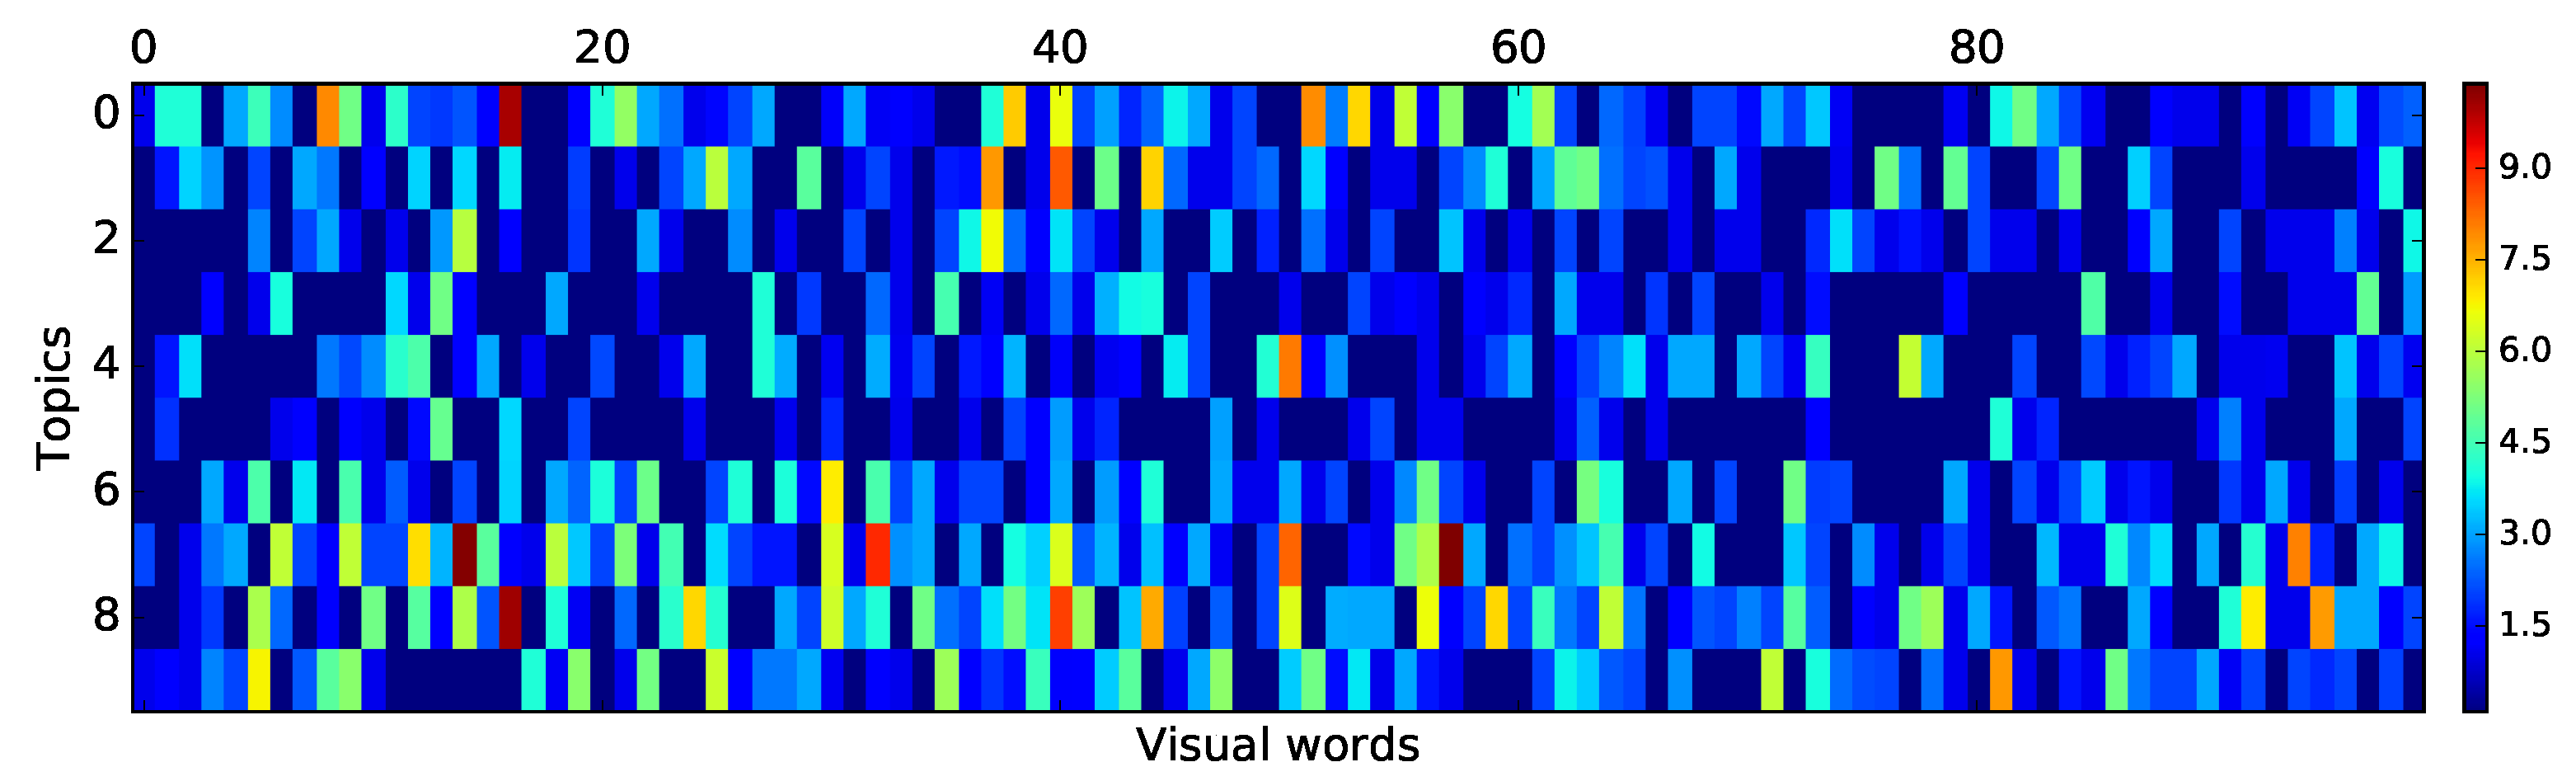
Physically-Interactive RoboGames (PIRG) are an emerging application whose aim is to develop robotic agents able to interact and engage humans in a game situation. In this framework, learning a model of players’ activity is relevant both to understand their engagement, as well as to understand specific strategies they adopted, which in turn can foster game adaptation. Following such directions and given the lack of quantitative methods for player modeling in PIRG, we propose a methodology for representing players as a mixture of existing player’s types uncovered from data. This is done by dealing both with the intrinsic uncertainty associated with the setting and with the agent necessity to act in real time to support the game interaction. Our methodology first focuses on encoding time series data generated from player-robot interaction into images, in particular Gramian angular field images, to represent continuous data. To these, we apply latent Dirichlet allocation to summarize the player’s motion style as a probabilistic mixture of different styles discovered from data. This approach has been tested in a dataset collected from a real, physical robot game, where activity patterns are extracted by using a custom three-axis accelerometer sensor module. The obtained results suggest that the proposed system is able to provide a robust description for the player interaction.
Keywords: robot games; human-robot interaction; player modeling; game design; latent Dirichlet allocation robot games; human-robot interaction; player modeling; game design; latent Dirichlet allocation