


Abstract
The capability of wind turbines (WTs) to provide frequency response is crucial for future power systems with high wind power penetration. Existing strategies primarily focus on mitigating initial and secondary frequency drop (SFD), often overlooking the adverse effects of rotor speed recovery on turbine safety and sustained grid support. Moreover, the lack of a dynamic linkage between the frequency support stage (FSS) and speed recovery stage (SRS) impedes multi-objective coordination encompassing initial drop suppression, SFD mitigation, and rapid rotor speed recovery. To address these gaps, this paper proposes a two-stage coordinated control strategy. In the FSS, the frequency regulation coefficients (Kp and Kd) are adaptively adjusted based on available kinetic energy, ensuring its rational release. Subsequently, the switching timing from FSS to SRS is optimized using these coefficients to suppress the SFD and accelerate recovery. Finally, a fuzzy logic-based PI controller dynamically governs the SRS to restore rotor speed efficiently while further alleviating the SFD. Simulation results confirm the effectiveness of the proposed strategy under two wind speeds. It improves the initial frequency nadir by up to 0.197 Hz over no frequency control, reduces the secondary frequency drop by as much as 0.106 Hz compared to the stepwise method, and accelerates rotor speed recovery by over 30%, quantitatively validating its superior coordinated performance.
1. Introduction
Amidst the accelerating global energy transition, renewable energy sources, particularly wind power, are progressively replacing conventional fossil fuel-based generation and becoming an integral component of modern power systems [1]. However, WTs are interfaced with the grid through power electronic converters. This interface decouples the rotor speed of the WTs from the grid frequency, thereby eliminating their natural inertial response to system frequency variations. Consequently, the system’s overall equivalent inertia is reduced, making frequency stability an increasingly critical challenge in power systems with high wind power penetration [2,3,4]. Therefore, enhancing the active frequency support capability of WTs is crucial for ensuring the secure and stable operation of future power systems dominated by renewable energy.
Wind turbine frequency regulation via rotor kinetic energy is implemented through two sequential stages: the FSS and SRS. In FSS, stored kinetic energy is released to provide active power support, mitigating the initial frequency nadir (Δfnadir1). The subsequent SRS restores rotor speed (ωr) to its optimal operating point, ensuring post-event stability and preserving future regulation capability [5]. However, the control objectives of the FSS and the SRS are intrinsically conflicting. During the FSS, aggressive kinetic energy release, while beneficial for raising the frequency nadir, inevitably leads to a deep rotor speed dip [6,7]. This complicates the subsequent SRS and presents a critical trade-off: a recovery strategy that is either too rapid or too conservative can each induce severe system issues. If the SRS employs an overly rapid strategy, such as a large stepwise power reduction, the resultant substantial electromagnetic power transient will cause a severe SFD. With improper control, the SFD magnitude can reach 80–120% of the initial frequency deviation [8,9], potentially triggering under-frequency load shedding and rapidly depleting system reserves. Conversely, an excessively conservative recovery strategy forces the wind turbine into prolonged low-speed operation. This impairs the power coefficient, reduces energy capture efficiency, and diminishes the turbine’s subsequent frequency regulation capability. Furthermore, sustained operation near the stall region exacerbates blade vibration and mechanical stress, raises safety concerns, and increases the risk of protective disconnection. Therefore, to ensure both overall frequency regulation effectiveness and device safety, it is crucial to appropriately harness the frequency regulation capability of wind turbines, achieving rapid rotor speed recovery while mitigating the SFD.
Although significant advancements have been made in wind turbine frequency regulation research, prevailing studies predominantly focus on the independent optimization of single stages, with an emphasis on suppressing the primary frequency drop and the SFD while largely neglecting the requirement for rapid rotor speed recovery. This single-objective paradigm consequently struggles to balance system frequency security with wind turbine operational stability. Specifically, during the FSS, existing strategies such as the dynamic droop control proposed in [10,11]—which gradually reduces output to mitigate the SFD—often lack adaptive calibration based on the real-time available kinetic energy. This limitation not only restricts the improvement of the frequency nadir but may also cause excessive rotor speed drops [12], thereby intensifying control difficulties in the subsequent SRS. Within the SRS, a clear trade-off exists: stepwise (ST) recovery methods [13] accelerate speed restoration at the cost of introducing secondary power impacts, whereas smooth recovery methods [14] suppress power fluctuations but risk insufficient recovery momentum in high penetration scenarios, prolonging low-speed operation and compromising economic and regulatory performance. Although adaptive parameter control using PI controllers has been introduced [15,16], its parameter tuning often fails to adequately consider the synergy between frequency regulation demands and turbine operating states, leading to suboptimal performance. Therefore, the simultaneous suppression of both the primary frequency drop (PFD) and SFD coupled with accelerated and stable rotor speed recovery remains a critical and unresolved challenge.
While the two-stage control paradigm (FSS and SRS) is widely adopted, a fundamental challenge persists in dynamically coordinating the transition between these stages. Existing frameworks often lack a systematically coupled architecture, and the switching logic is typically not governed by rigorous, quantitative decision-making criteria. For instance, strategies proposed in [17,18] aim to mitigate the SFD by delaying recovery initiation or smoothing the power trajectory. However, these approaches do not establish a dynamic correlation between the switching conditions and the real-time frequency state of the power system. As a result, the timing of stage transitions may not optimally align with the grid’s actual recovery needs. Although integrated two-stage frameworks have been developed [19,20], their switching conditions are often preset and relatively inflexible. This can lead to fragmented stage-to-stage control and limit the framework’s adaptability to the highly dynamic operating conditions of modern power grids with high renewable penetration.
Beyond the technical coordination challenges, the practical implementation of the control strategy must also consider its economic viability. The cost of implementing the frequency regulation strategy primarily arises from software development and controller upgrades, as it leverages existing turbine hardware and measurement data. More critically, the intelligent recovery strategy minimizes energy loss by accelerating rotor speed recovery. This approach reduces the duration of suboptimal turbine operation, thereby mitigating its impact on the Levelized Cost of Energy (LCOE). Consequently, the service becomes more sustainable from an operator’s perspective. Moreover, the enhanced grid support capability can itself generate value through future ancillary service markets or by facilitating compliance with grid codes.
In summary, wind turbine frequency regulation is characterized by dynamic multi-timescale coupling and inherent multi-objective conflicts. Current control strategies face two principal shortcomings: They neither coordinate the dual objectives of suppressing both primary and secondary frequency drops while ensuring rapid rotor speed recovery, nor do they provide systematic criteria for switching between the frequency support and speed recovery stages. As a result, conventional single-stage or simple sequential control architectures cannot achieve holistic optimization across the complete regulation sequence—from initial dip suppression through SFD mitigation to swift recovery. This fundamental gap substantially limits the overall performance enhancement of wind turbine frequency regulation. To bridge this gap, this paper proposes a two-stage coordinated control strategy designed for multi-objective synergy in wind turbine frequency regulation. The main contributions are outlined below:
- (1)
- During the frequency support stage, the frequency regulation potential of doubly fed wind turbines under varying wind speeds was analyzed. The overall inertia coefficient (Kp and Kd) was optimized by jointly considering the releasable rotational kinetic energy and the associated power losses due to speed reduction, establishing a wind-speed-dependent determination method for this coefficient.
- (2)
- The impact of the switching point between the FSS and the SRS on the secondary frequency drop was investigated. Based on the frequency modulation coefficient set during the FSS and the system’s inherent parameters, the optimal switching timing for minimizing the SFD magnitude was determined.
- (3)
- For the SRS, a fuzzy PI controller was designed to suppress the SFD and accelerate rotor speed recovery. The controller adapts its initial coefficients based on the rotor kinetic energy released during the preceding FSS and employs a dynamic adjustment strategy to update its PI parameters in real-time according to the recovery progress. This approach thereby mitigates the SFD, expedites recovery, and enhances system resilience against secondary disturbances.
The paper is structured as follows. Section 2 analyzes the two-stage control mechanism for wind turbine primary frequency regulation. Section 3 details the proposed framework, including the evaluation of frequency regulation potential, determination of stage-switching criteria, and design of the segmented control strategy. Section 4 validates the strategy through case studies and compares its performance with existing methods. Finally, Section 5 concludes with the key findings.
2. Analysis of Wind Turbine Units Participating in Primary Frequency Regulation
The frequency regulation capability of WTs is crucial for maintaining system stability. This section analyzes the operational characteristics of WTs and elaborates on the two-stage FR process. The analysis focuses on the control mechanisms in both the FSS and the SRS, while also addressing associated issues such as abrupt power changes and the SFD.
2.1. Analysis of Wind Turbine Operational Characteristics
The electrical output power of a WT is derived from the mechanical power captured by its rotor and is governed by the following expression:
In (1), Cp represents the power coefficient, which is a function of the tip speed ratio λ and the blade pitch angle β. This expression describes the fundamental aerodynamic energy conversion principle common to all wind turbines. While the general functional dependency Cp(λ, β) is universal, its specific numerical form is determined by the aerodynamic design of the turbine, such as blade geometry. To formulate a general control strategy, this paper adopts this universal relationship. The specific parameters used in the expression correspond to a widely adopted doubly fed induction generator (DFIG) model. ρ denotes the air density, v the wind speed, R the rotor radius, ωr the rotor rotational speed and Pm the mechanical power of the WT.
For a given blade pitch angle β, there exists an optimal tip speed ratio λopt that maximizes the power coefficient Cp. Operating at this λopt enables the WT to achieve maximum power point tracking (MPPT). The corresponding active power output PMPPT is expressed as:
In (2), Kopt denotes the optimal power coefficient, which encapsulates the aerodynamic characteristics of the turbine. Consequently, the WT’s active power reference is regulated to track this MPPT curve.
The dynamics of the drive train in a WT are commonly described by the following equations:
In (3), HDFIG is the inertia time constant of the WT, and Pw denotes its electromagnetic power. Pm is the mechanical power. This equation describes the variation in the rotor speed ωr with the output power during the WT’s participation in frequency regulation.
2.2. Analysis of the Two-Stage Frequency Regulation Process in Wind Turbines
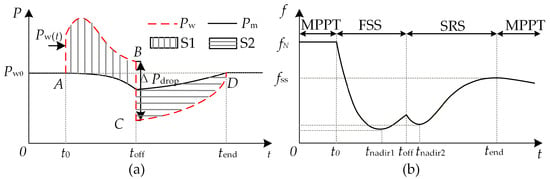
The frequency regulation of a WT following a system disturbance comprises two stages: the frequency support stage (FSS) and the speed recovery stage (SRS) (see Figure 1).
Figure 1.
Schematic of the two-stage frequency regulation process in wind turbines: (a) Active power output; (b) System frequency response.
(1) Frequency Support Stage (t0-toff).
During the FSS, the primary control objective is to release the stored rotor kinetic energy for grid frequency support, thereby raising the frequency nadir. Following a system disturbance, the WT generates additional power beyond the PMPPT. The electromagnetic power of the WT during FSS is thus expressed as:
In this expression, ΔPadd denotes the additional power output, which is determined by the specific frequency regulation control strategy implemented in the WT.
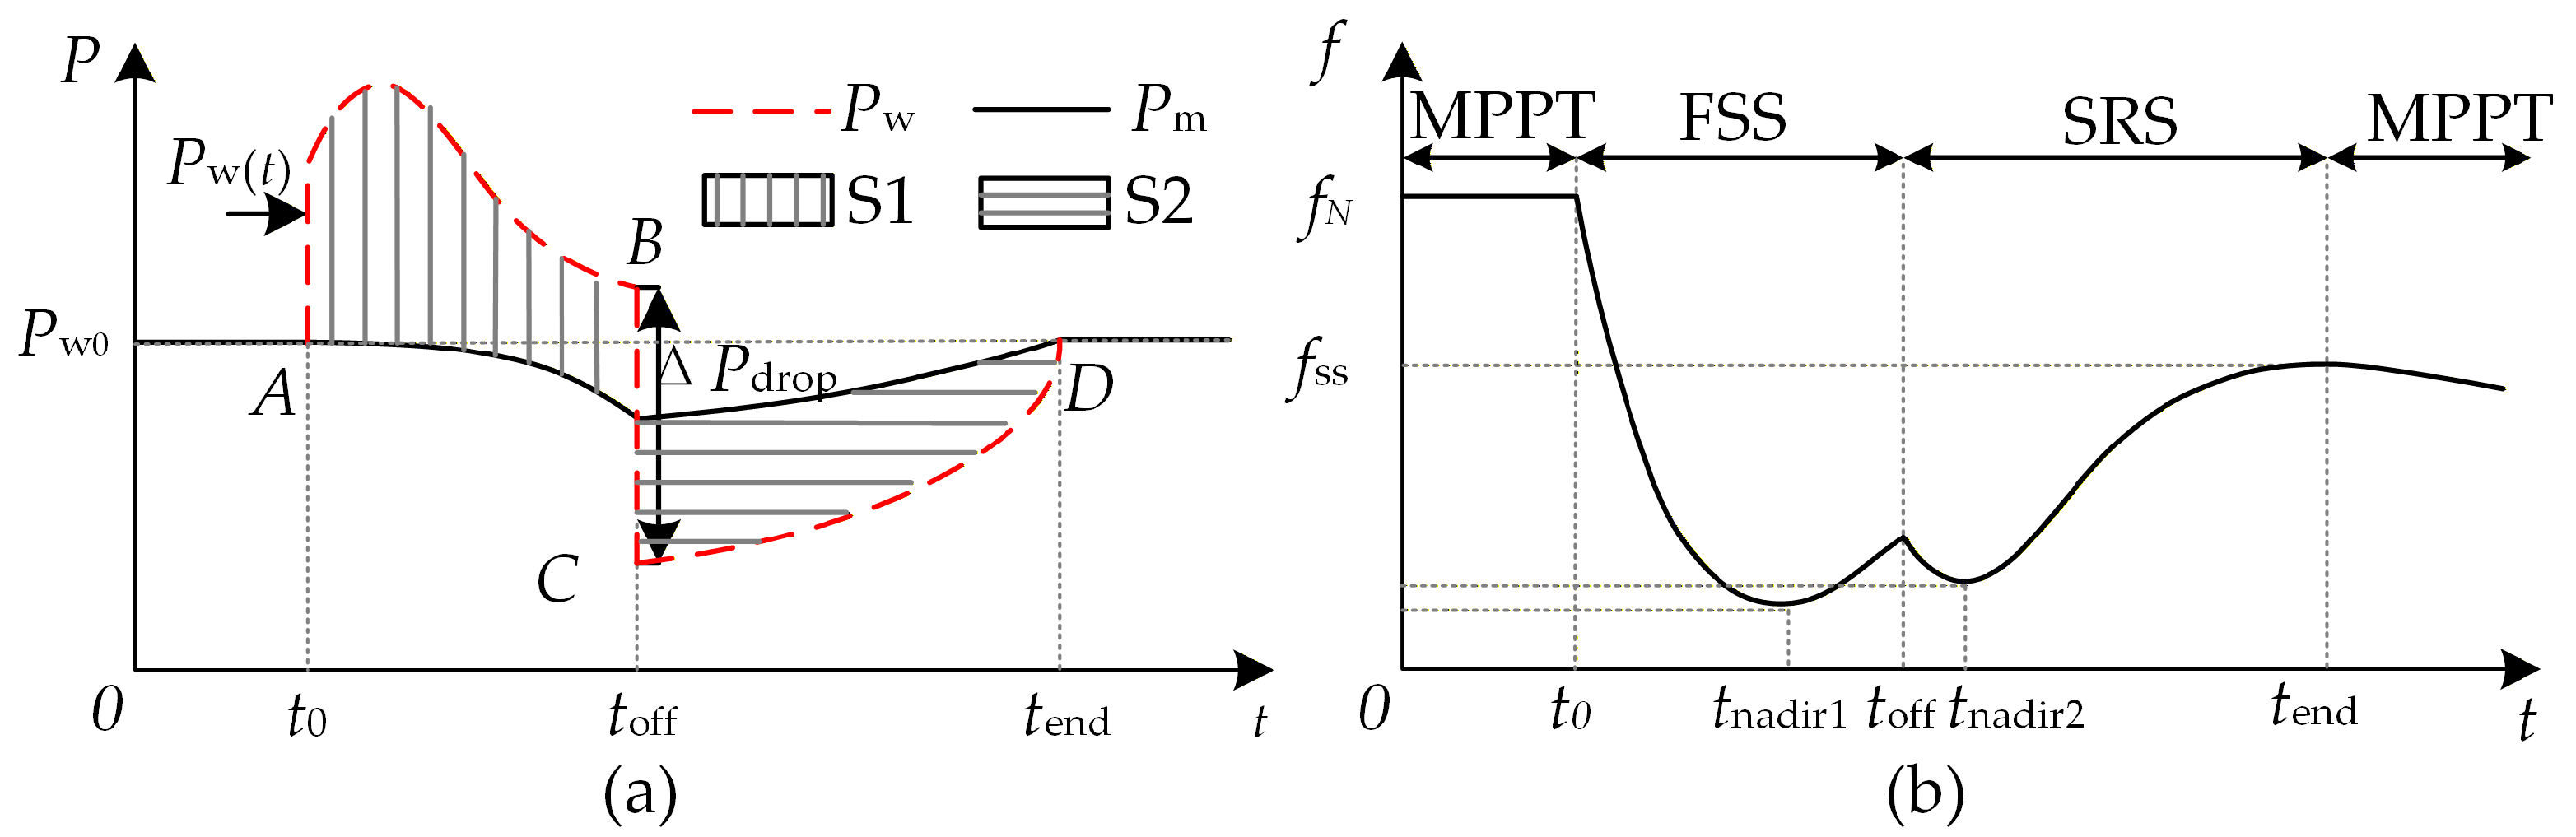
When the WT employs synthetic inertia control, the corresponding control block diagram is presented in Figure 2a. The additional power ΔPadd is then given by:
Figure 2.
Block diagram of the two-stage frequency regulation strategy for WTs: (a) Synthetic inertia control during the FSS; (b) PI-based rotor speed recovery control during the SRS.
In this formulation, Δf denotes the system frequency deviation, df/dt is the rate of change of frequency (ROCOF), Kd is the inertial response coefficient, and Kp is the droop control coefficient. The injection of ΔPadd thus enhances the system’s ROCOF and raises the frequency nadir. Upon reaching the frequency nadir, the primary task of the FSS is accomplished. The WT consequently enters a deceleration and load-shedding state, as the release of stored rotor kinetic energy leads to a reduction in rotor speed ωr. This deceleration forces the WT to operate away from its optimal (MPPT) point.
(2) Rotor Speed Recovery Stage (toff-tend).
The primary control objective of the SRS is to rapidly restore the WT’s rotor speed, which has declined due to the prior kinetic energy release, thereby avoiding prolonged operation in a derated state. According to the rotor dynamics described by (3), a necessary condition for rotor speed recovery is that the electromagnetic power (Pw) remains lower than the mechanical power (Pm).
The PI controller generates the power reduction reference ΔPdrop based on the deviation of the rotor speed from its optimal setpoint and the integral of this deviation. The overall frequency regulation strategy integrating this PI-based recovery control is depicted in Figure 2b.
The electromagnetic power reference for the WT during SRS is thus given by:
During the SRS, the system frequency gradually approaches a quasi-steady state. The influence of ΔPadd from the synthetic inertia control gradually diminishes, while the power reduction ΔPdrop becomes the dominant factor governing the rotor speed recovery. To initiate effective speed recovery, a substantial initial ΔPdrop is typically applied at the transition instant toff. As the recovery progresses, the dynamics of the WT are governed by the combined effects of its mechanical characteristics, the MPPT control, and the rotor motion dynamics described by (3). When the rotor speed recovers to its initial value ωr0, the electromagnetic power (Pw), mechanical power (Pm), and the MPPT power (PMPPT) converge. Consequently, the WT returns to its pre-disturbance operating state.
Conventional speed recovery strategies typically apply a stepwise power reduction, ΔPdrop, at the instant toff, instantly decreasing the electromagnetic power Pw to the MPPT power level. This creates a significant instantaneous imbalance between the mechanical power Pm and the electromagnetic power Pw, which induces a high rate of change in rotor speed and thus enables fast recovery. However, this stepwise power reduction effectively introduces a secondary power disturbance into the system at toff. This imbalance power ΔPun(toff) can be expressed as:
A larger ΔPdrop results in a greater net accelerating power, which in turn induces a more severe SFD. Therefore, in designing frequency regulation strategies for WTs, it is crucial to not only achieve the stage-specific control objectives but also to ensure coordinated transitions between control modes to effectively mitigate the SFD.
3. Design of a Two-Stage Adaptive Frequency Regulation Control Strategy
This section details the design of the proposed control strategy. It encompasses: (1) the adaptive determination of frequency regulation parameters (Kp and Kd) for WTs during the FSS; (2) a method for selecting the two-stage switching point to mitigate the SFD; and (3) the design of a fuzzy-PI controller for the SRS. These components are integrated to form the complete two-stage adaptive frequency regulation control scheme.
3.1. Frequency Support Stage Strategy Based on Available Kinetic Energy
To effectively harness the frequency regulation potential of WTs across different wind speeds while mitigating the initial frequency drop and preventing excessive rotor speed depletion, this paper proposes a constrained maximum power increment model. This model serves as the basis for adaptively calibrating the frequency regulation coefficients.
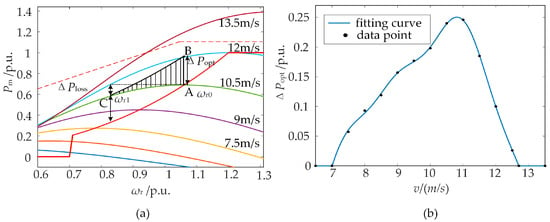
The kinetic energy stored in the WT rotor and its available power output vary with wind speed. Consequently, the design of the power increase must consider the converter’s current limit, the rotor’s torque limit, and the available kinetic energy dictated by the instantaneous wind speed. Figure 3a shows the power response of a doubly fed induction generator during a frequency drop. Following the frequency drop, the WT increases its power output from the initial operating point (A) to the maximum achievable point (B), utilizing the rotor’s kinetic energy. In the absence of a speed recovery strategy, the system eventually settles at a new equilibrium (C). At point C, the reduced rotor speed results in a lower power capture efficiency, incurring a mechanical power loss ΔPloss. This illustrates that part of the released kinetic energy is used for frequency support, while another portion is dissipated to cover the increased mechanical loss ΔPloss.
Figure 3.
DFIG frequency regulation: (a) Rotor kinetic energy release of a DFIG for frequency regulation; (b) Maximum power increment of the WT versus wind speed.
To maximize the frequency regulation capability of WTs within operational limits, this paper defines the optimization objective as the maximum available power for FR at a given wind speed. This is quantified as the net power contributed by the rotor kinetic energy release, deducting the mechanical loss ΔPloss incurred at the post-support equilibrium. This yields the maximum feasible power increment, denoted as ΔPopt, which can be delivered beyond the pre-disturbance MPPT level (PMPPT). Subject to the constraints of converter current, rotor torque, and rotor speed, the optimization model is formulated as follows:
In (8), Pm(v, ωr0) and Pm(v, ωr1) represent the mechanical power of the WT at wind speed v corresponding to the initial rotor speed ωr0 and the post-support speed ωr1, respectively. Tmax is the maximum allowable torque of the drive train. Pw,max is the converter’s maximum power rating. T is the typical duration of the frequency support process. Solving the optimization model (8) yields the maximum available power increment ΔPopt across a range of wind speeds. A fitted curve characterizing the relationship between ΔPopt and wind speed υ is presented in Figure 3b.
Throughout the entire frequency event, the total active power output of the WT under synthetic inertia control must satisfy the following constraint:
In synthetic inertia control, the allocation of the released kinetic energy determines the values of the inertial response coefficient Kd and the droop control coefficient Kp, which govern the system’s frequency response characteristics. The inertial response (governed by Kd provides rapid power support to restrain the rate of change of frequency (ROCOF), with its effectiveness proportional to Kd. Conversely, droop control (governed by Kp primarily elevates the frequency nadir but has negligible impact on the ROCOF.
Based on the preceding analysis, a hierarchical power allocation strategy is proposed: the inertial response is designated as the primary (priority) control loop. Following a disturbance, the coefficient Kd is tuned using the system’s initial ROCOF, which is defined as its maximum value |df/dt|max. This ensures rapid power injection at the onset of a disturbance, thereby enhancing the system’s initial dynamic response. The tuning rule for Kd is given by:
In (10), ΔPopt (v) is the maximum available power increment defined in Section 3.1, and β is the power allocation coefficient between inertial and droop responses. Given that the inertial response contributes to both ROCOF restraint and frequency nadir elevation, its allocated power share can be weighted higher. Based on engineering practice, β is commonly selected within the range of 0.5 to 0.7.
The inertial response provides only short-duration, transient power support. To ensure sustained power support following the transient response, a portion (30–50%) of ΔPopt is allocated to the droop control during the FSS. Following the definition of the synchronous generator’s (SG) frequency regulation coefficient, the droop coefficient Kp is expressed as [21]:
In (11), Ep denotes the energy allocated to the droop response, and ΔPdrop represents the corresponding active power. By expressing the equation in per-unit terms and assuming the maximum permissible frequency deviation Δfmax = 0.01 p.u. for analytical simplification, we obtain a normalized form. Rearranging this expression yields the following formulation for the droop coefficient Kp:
In summary, the proposed design utilizes real-time wind speed data to determine the maximum available power increment, ΔPdrop, derived from the optimization model presented in this section. This, in turn, enables the adaptive determination of the frequency regulation coefficients, Kd and Kp, thereby maximizing the frequency regulation capability of the WT.
3.2. On the Mechanism of Secondary Frequency Drop Influenced by the FSS-to-SRS Switching Time (toff)
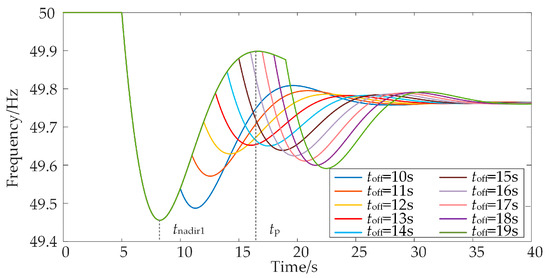
Initiating rotor speed recovery requires that the electromagnetic power Pw of the WT be reduced below its mechanical power Pm. This is achieved by introducing a power reduction ΔPdrop at the switching instant toff. However, this essential action inherently introduces a secondary power disturbance into the grid, which is the direct cause of the SFD. As evidenced by the simulation results in Figure 4, for a given ΔPdrop, the severity of the resulting SFD exhibits significant nonlinear dependence on the chosen toff. Specifically, after the initial frequency nadir (at time tnadir1), the magnitude of the SFD demonstrates a non-monotonic dependence on the delay period toff, showing an initial improvement followed by a deterioration.
Figure 4.
Frequency response curves at different two-stage switching moments.
To precisely elucidate the influence mechanism of the delay time toff on the SFD, it is essential to develop a mathematical model encompassing the entire frequency support process. The core principle of the two-stage coordinated control strategy proposed in this paper is as follows: at the switching instant toff, the WT does not abruptly exit frequency regulation as in conventional strategies. Instead, it superimposes a controlled power reduction ΔPdrop onto the ongoing fundamental frequency support component. From a system perspective, this action is equivalent to introducing a step disturbance of magnitude ΔPdrop at toff. This modeling approach provides a more physically accurate representation: a controlled power deficit is actively introduced to initiate speed recovery while preserving the essential frequency support. This design ensures that the WT continues to provide damping to the grid throughout its kinetic energy recovery transition, thereby effectively mitigating the secondary power shock inherent in conventional step-exit strategies. This coordinated process can be uniformly described by the following expression:
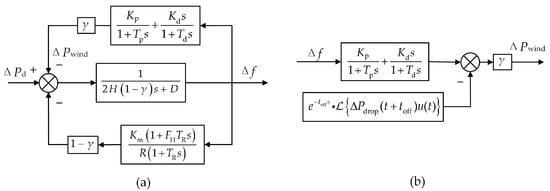
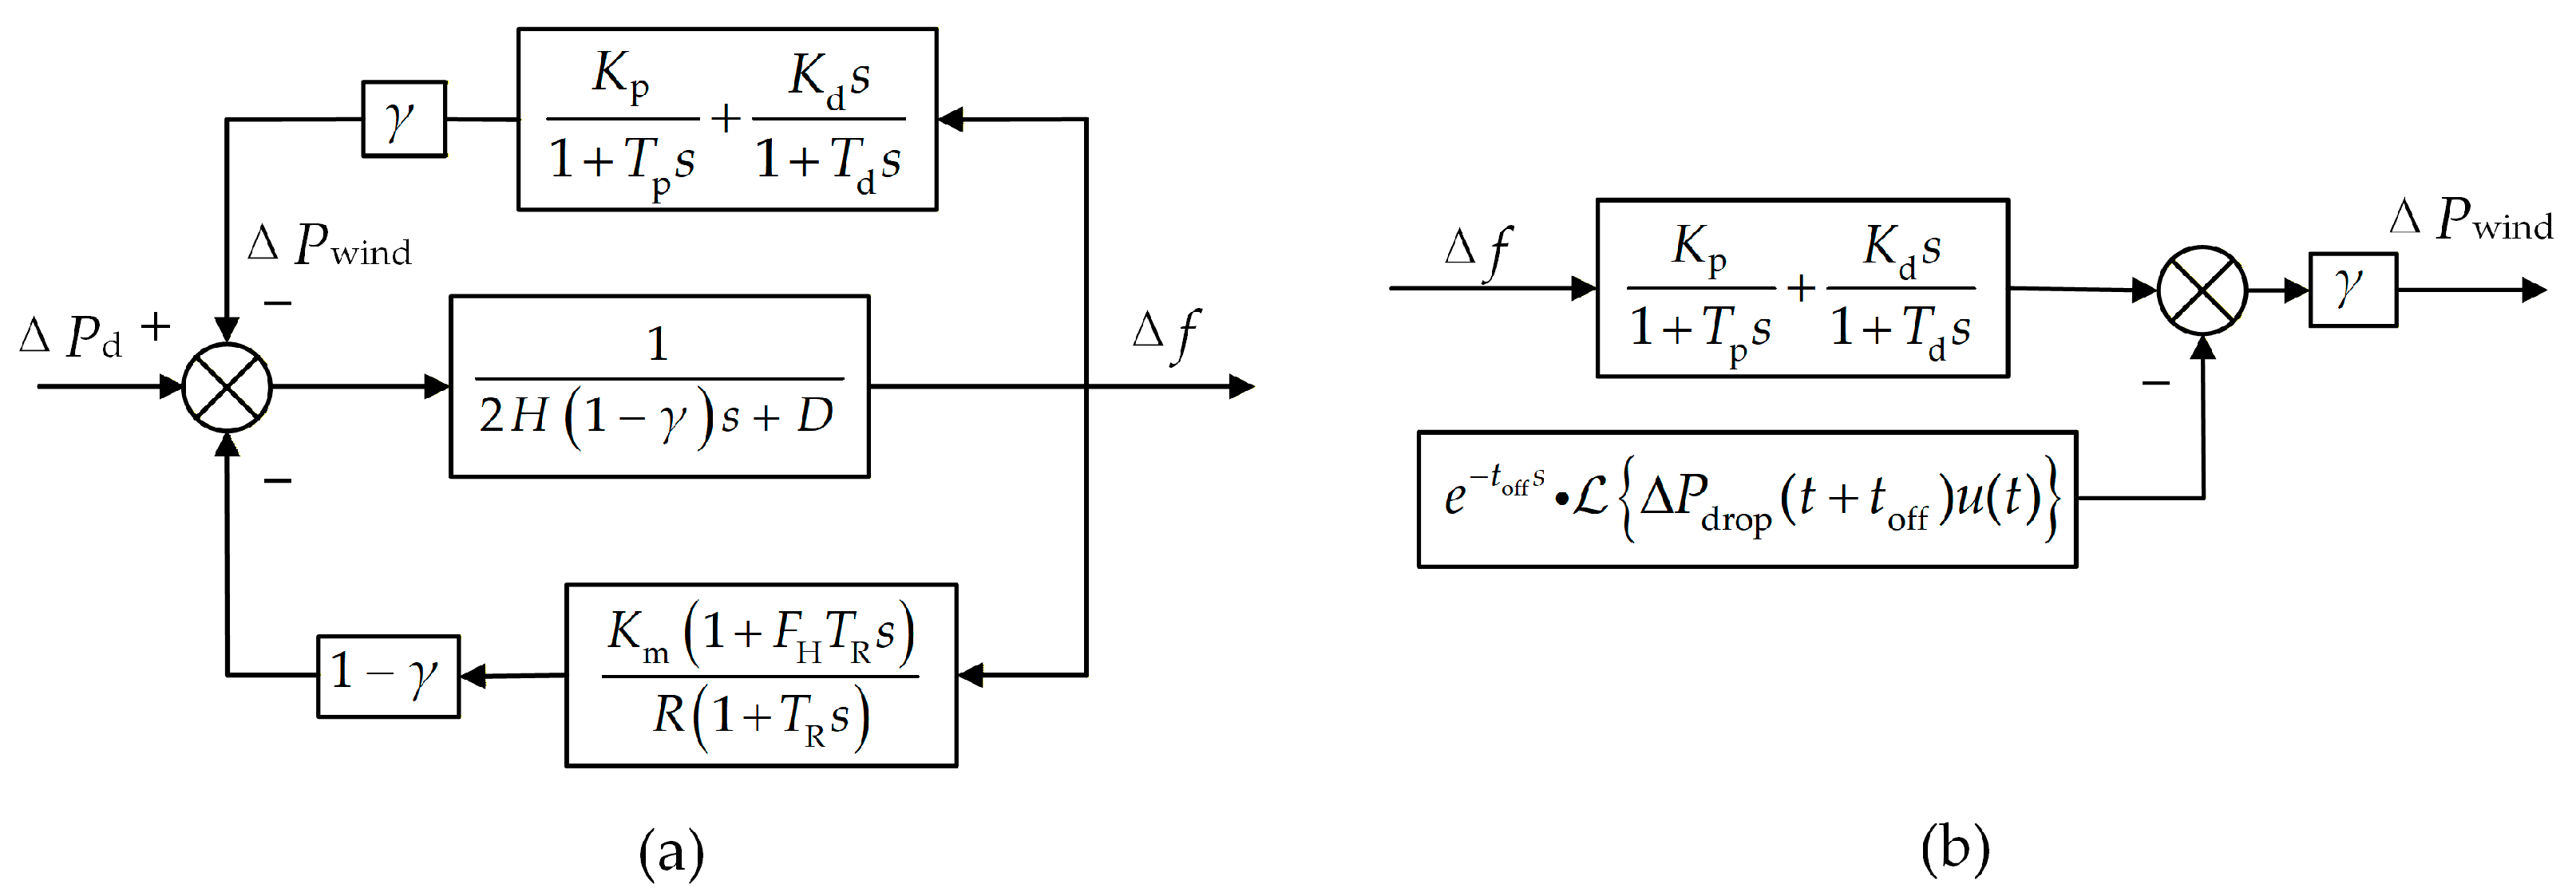
To analyze the dynamic impact of the WT’s power variation on the system frequency, the WT model is integrated into the aggregated low-order equivalent power system model from [22]. In this context, Kd and Kp are the droop control coefficient and the virtual inertia coefficient, respectively, while Tp and Td represent the time constants of the droop control loop and the inertia control loop, respectively. Given that the time constants of the wind power control loops are considerably smaller than the reheat time constant TR, their influence is neglected in the subsequent analysis. For the detailed definitions of other synchronous generator parameters, please refer to the list of abbreviations.
Figure 5a shows the system block diagram during the frequency support stage. In this diagram, the WT’s synthetic inertia control loop, which includes the inertial response coefficient Kd and the droop control coefficient Kp, is integrated as a negative feedback path. Figure 5b presents the power expression during the speed recovery stage, initiated at time toff. It clearly shows the superposition of ΔPdrop onto the existing frequency support power.
Figure 5.
Unified model of the two-stage wind turbine frequency regulation: (a) system block diagram with synthetic inertial control; (b) power adjustment mechanism at the switching instant.
Based on this unified model, the transfer function relating the system frequency deviation to the net power disturbance can be derived and rearranged into a standard underdamped second-order form:
where ζ denotes the damping ratio and ωn represents the natural frequency, with their specific expressions given by Equation (15).
This formulation indicates that the post-disturbance frequency dynamic response characteristics of the system are determined by ζ and ωn. These two parameters are, in turn, jointly influenced by the inherent system parameters (such as H, D, R, and TR) and the wind turbine frequency regulation parameters (Kd and Kp).
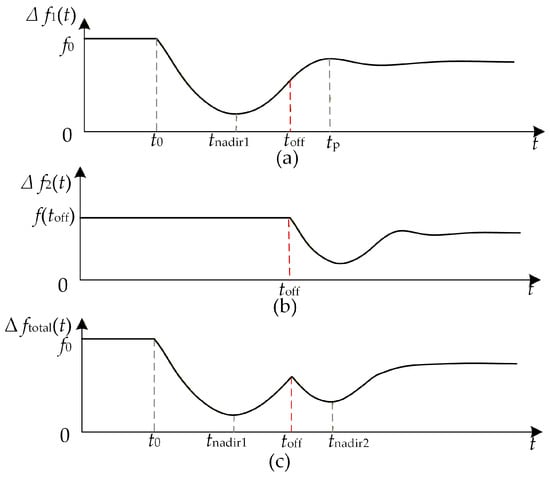
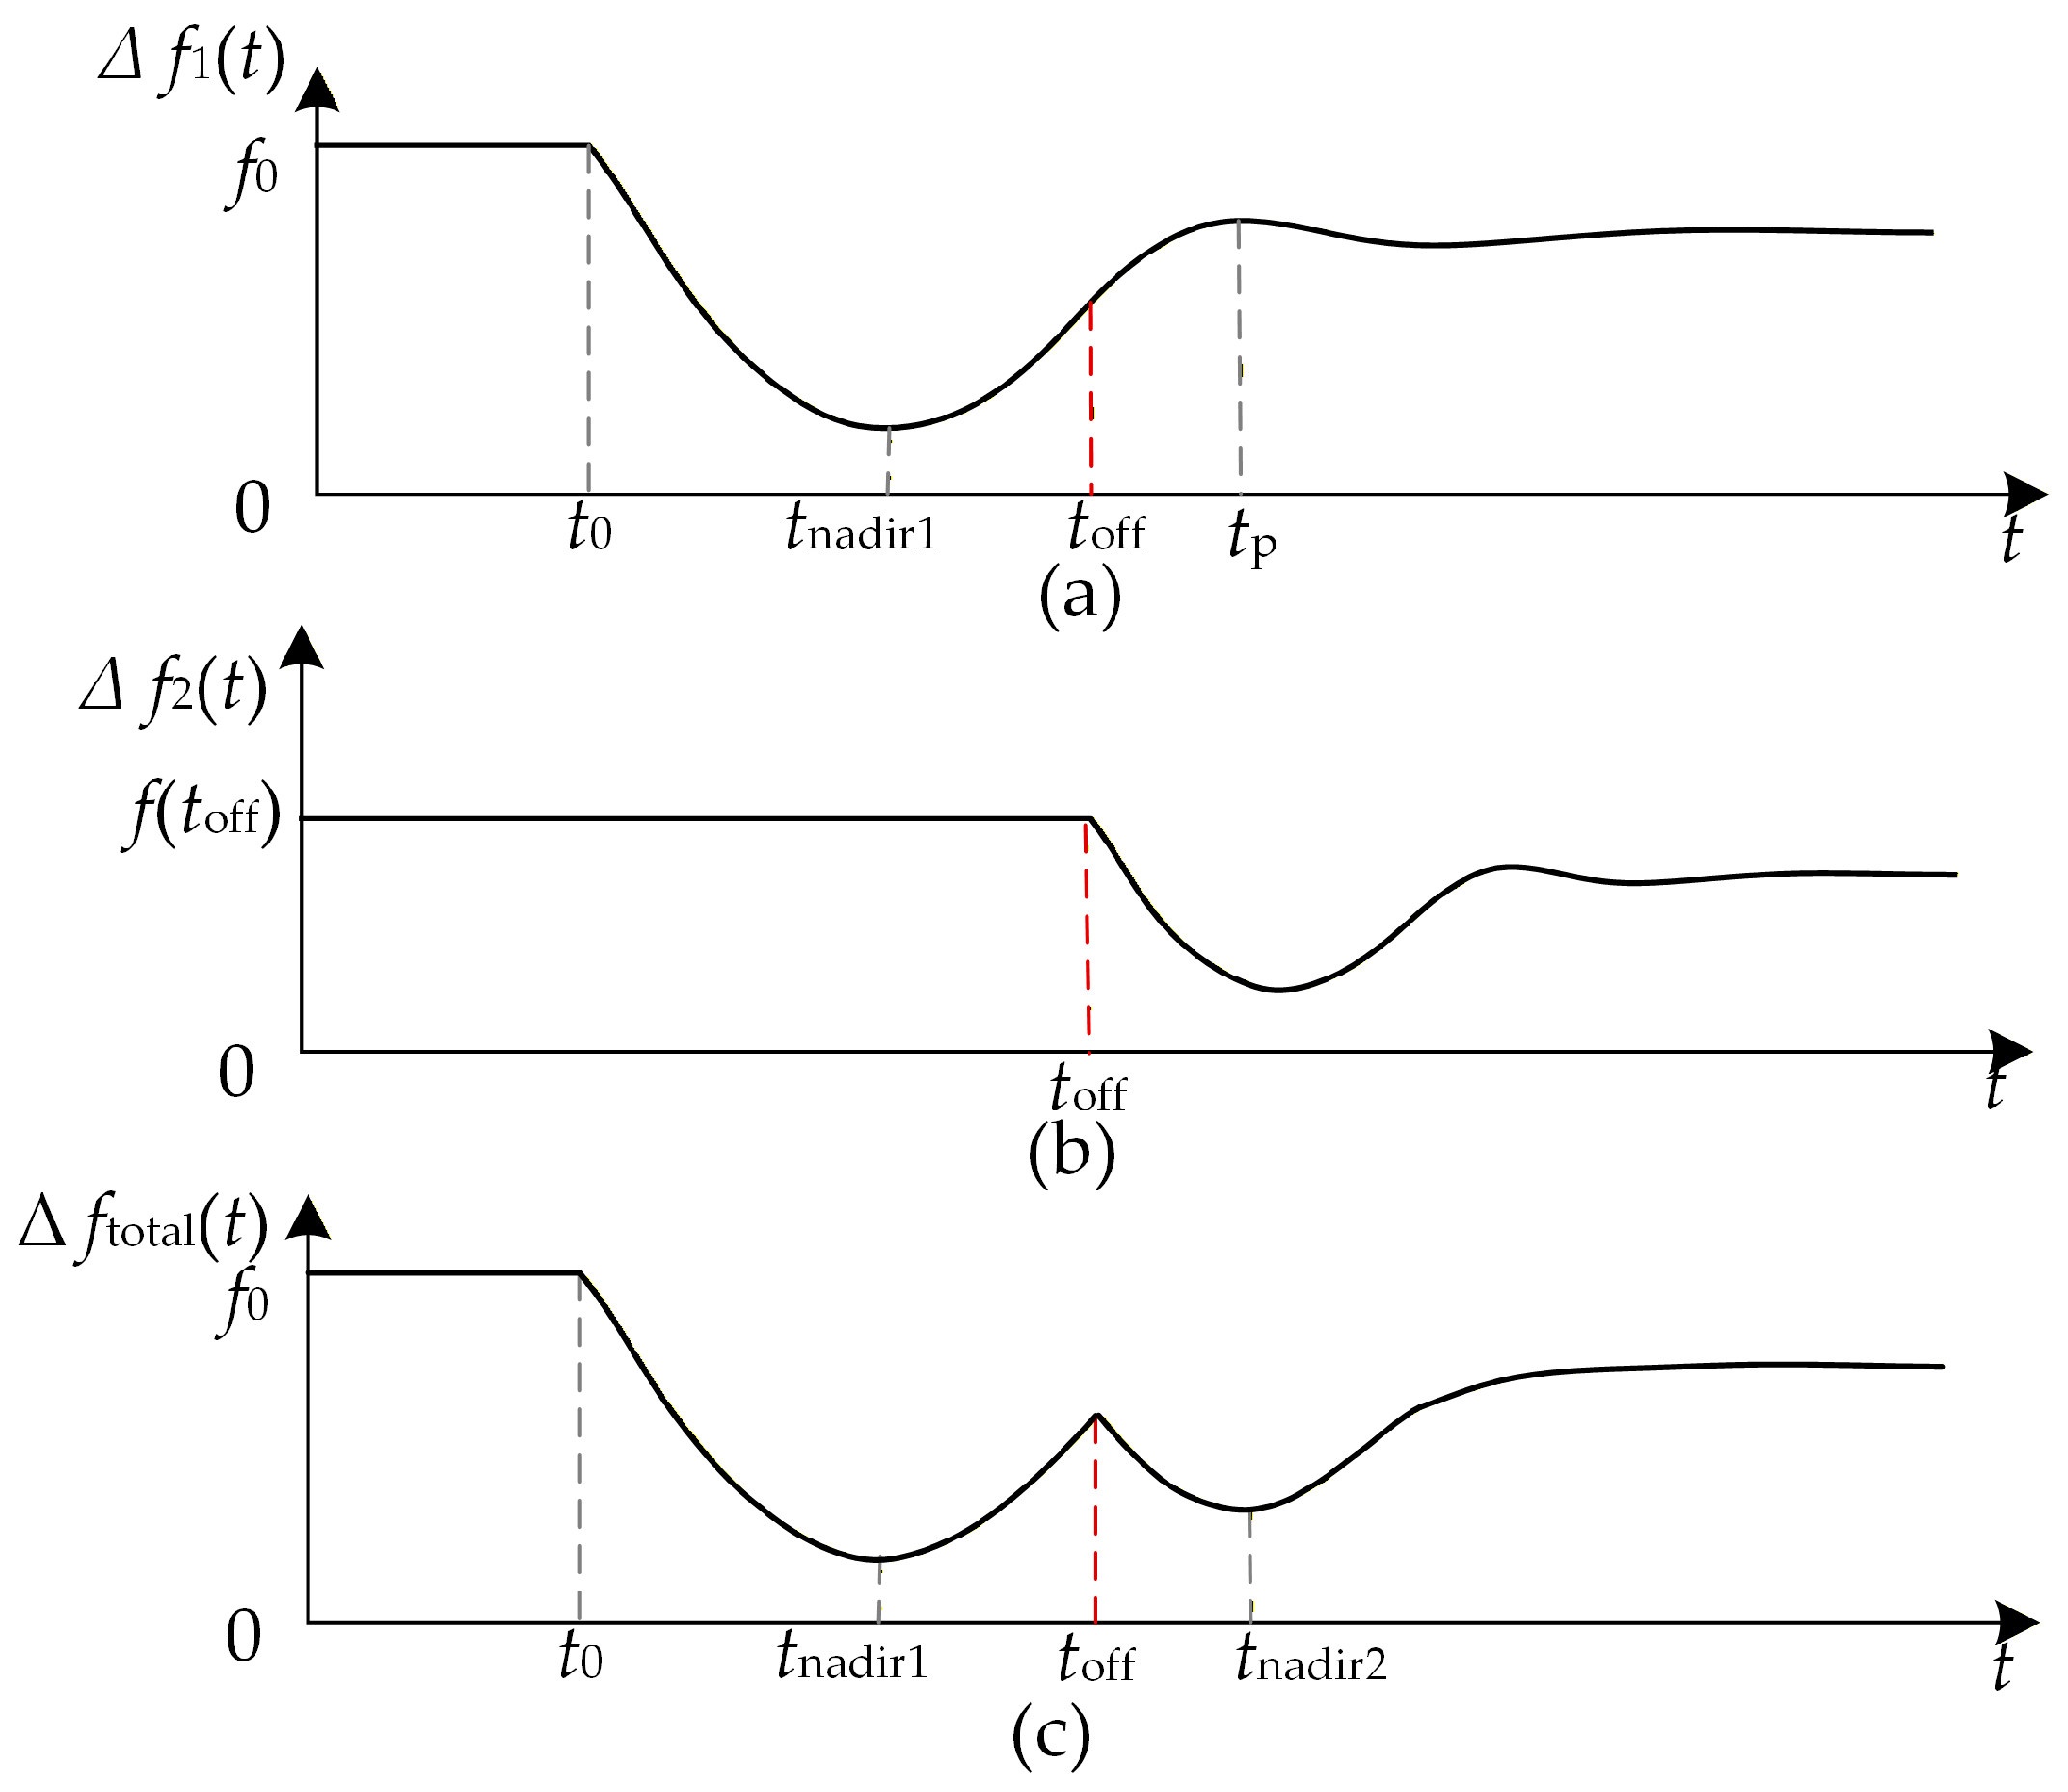
Under the condition of constant system parameters and fixed frequency regulation coefficients, the system can be approximated as a linear time-invariant (LTI) system for analysis. According to the principle of linear superposition, the total frequency response Δftotal(t) during the rotor speed recovery stage (t > toff) can be decomposed into the superposition of two independent components:
(1) Frequency Response Component from the Initial Disturbance: Δf1(t).
The inherent system response, Δf1(t), initiated by a sudden load increase ΔPL at t0, exhibits dynamic characteristics governed by the synchronous generator’s inertia constant H, damping coefficient D, and the tuned control parameters Kd and Kp, as described by:
In the formula:
This response exhibits typical underdamped oscillatory characteristics. Its overshoot Δfovershoot and peak time tp can be expressed as:
In (18), Δfss denotes the steady-state frequency deviation, determined by system parameters and the load disturbance ΔPL. Furthermore, it can be derived from the above expressions that the peak time tp depends exclusively on the system parameters and remains unaffected by the amplitude of the disturbance.
(2) Control the exit response component Δf2(t).
The power reduction ΔPdrop, applied via the PI controller at time toff, induces an additional frequency response, denoted as Δf2(t). During the subsequent brief recovery period, the active power output of the WT varies only gradually. Within this short time window, the frequency dynamics are dominated by the impulsive excitation of the step change ΔPdrop (toff), which is linked to the system’s dominant pole [23]. Therefore, to simplify the analysis of frequency dynamics during the speed recovery stage (SRS), it is reasonable to consider only the initial step disturbance ΔPdrop (toff), neglecting the subsequent gradual variations in the WT’s active power. Reference [23] confirms that the error introduced by this simplification remains within an acceptable range. Consequently, the expression for the simplified frequency response component Δf2(t) is derived as follows:
According to the superposition principle of linear systems, the overall frequency response of the system throughout the entire frequency regulation process can be expressed as:
It is evident that key synchronous generator parameters (H, D, and TR) and the WT frequency regulation coefficients (Kd and Kp) influence the system’s natural frequency ωn and damping ratio ζ, thereby governing the dynamic characteristics of the frequency response. Due to the homogeneity property of linear systems, the magnitude of a power disturbance primarily scales the absolute value of the frequency deviation, while exerting negligible influence on the critical temporal characteristics of the dynamic response, such as the timing of its extreme points. This property inherently ensures the robustness of the toff tuning strategy with respect to unknown disturbance magnitudes.
Combining the simulation results of Figure 5 with the two-stage frequency response decomposition in Figure 6 reveals that when toff is set between tnadir1 and tp, the response drop Δf2(t) induced by ΔPdrop interacts with the system’s overshoot component Δf1(t) in the time domain as follows:
Figure 6.
Two-stage SFR frequency response components and superimposed quantities: (a) Frequency response component induced by ΔPd; (b) Frequency response component caused by ΔPdrop (toff); (c) Two-stage frequency response superposition quantity.
An in-depth analysis of the toff influence mechanism is conducted by examining its timing relative to the first frequency nadir (tnadir1) and the overshoot peak time (tp). When toff occurs no later than tnadir1, Δf2(t) is introduced while Δf1(t) is still in its initial decline or at its nadir. The resulting in-phase superposition of these two components exacerbates the depth of the SFD. Conversely, if toff is delayed until after tp, Δf1(t) has already passed its peak and is in the decay phase. The compensating effect of the subsequently introduced Δf2(t) is therefore minimal, offering little mitigation of the SFD. The optimal condition is achieved when toff is selected within the interval between tnadir1 and tp. During this period, Δf1(t) is rising towards its overshoot peak. A deliberate choice of toff within this window enables an advantageous temporal alignment where the excessive upward swing of Δf1(t) partially offsets the downward dip of Δf2(t). This interference effectively elevates the minimum point (nadir) of the composite frequency response, thereby minimizing the SFD.
3.3. Optimization of the Switching Timing (toff) for the Two-Stage Coordinated Control Strategy
Achieving the optimal switching time toff to mitigate the SFD requires precise temporal alignment between the negative valley of Δf2(t) and the positive overshoot of Δf1(t), thereby elevating the overall response nadir. However, Δftotal(t) is a highly nonlinear and non-convex function of toff, making direct analytical optimization intractable. Therefore, this paper proposes a hybrid approach integrating quantitative modeling with intelligent optimization to determine the optimal toff across varying frequency regulation parameters.
First, key system parameters, including the equivalent generator inertia constant H and damping coefficient D, are identified offline. These are then integrated with the WT’s tuned frequency regulation parameters (Kd, Kp) to construct a system transfer function model for simulating frequency dynamics. Based on this model, an optimization problem is formulated with the objective of minimizing the amplitude of SFD.
Here, Δftotal(t) is the frequency deviation during the speed recovery stage, and denotes the objective to minimize the amplitude of the SFD.
An improved particle swarm optimization (PSO) algorithm is employed to solve this optimization problem. The parameter settings are as follows: the inertia weight w adopts a linear decay strategy from 0.9 to 0.4; the individual learning factor and population learning factor are set to c1 = c2 = 1.49; during algorithm iteration, the particle state is updated according to Equation (23):
In (23), xik and vik denote the position and velocity of particle i at iteration k, respectively; pik and gk represent the particle’s personal best position and the population’s global best position, respectively; r1 and r2 are random numbers uniformly distributed in the interval [0, 1]. Constraining the search space within the interval [tnadir1, tp] and introducing a boundary penalty function enhances the convergence of the optimization algorithm.
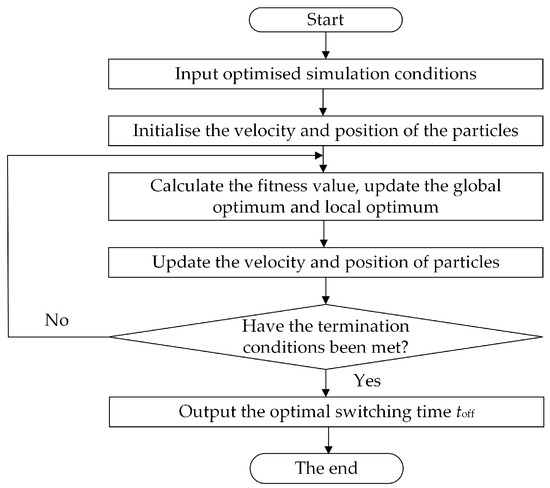
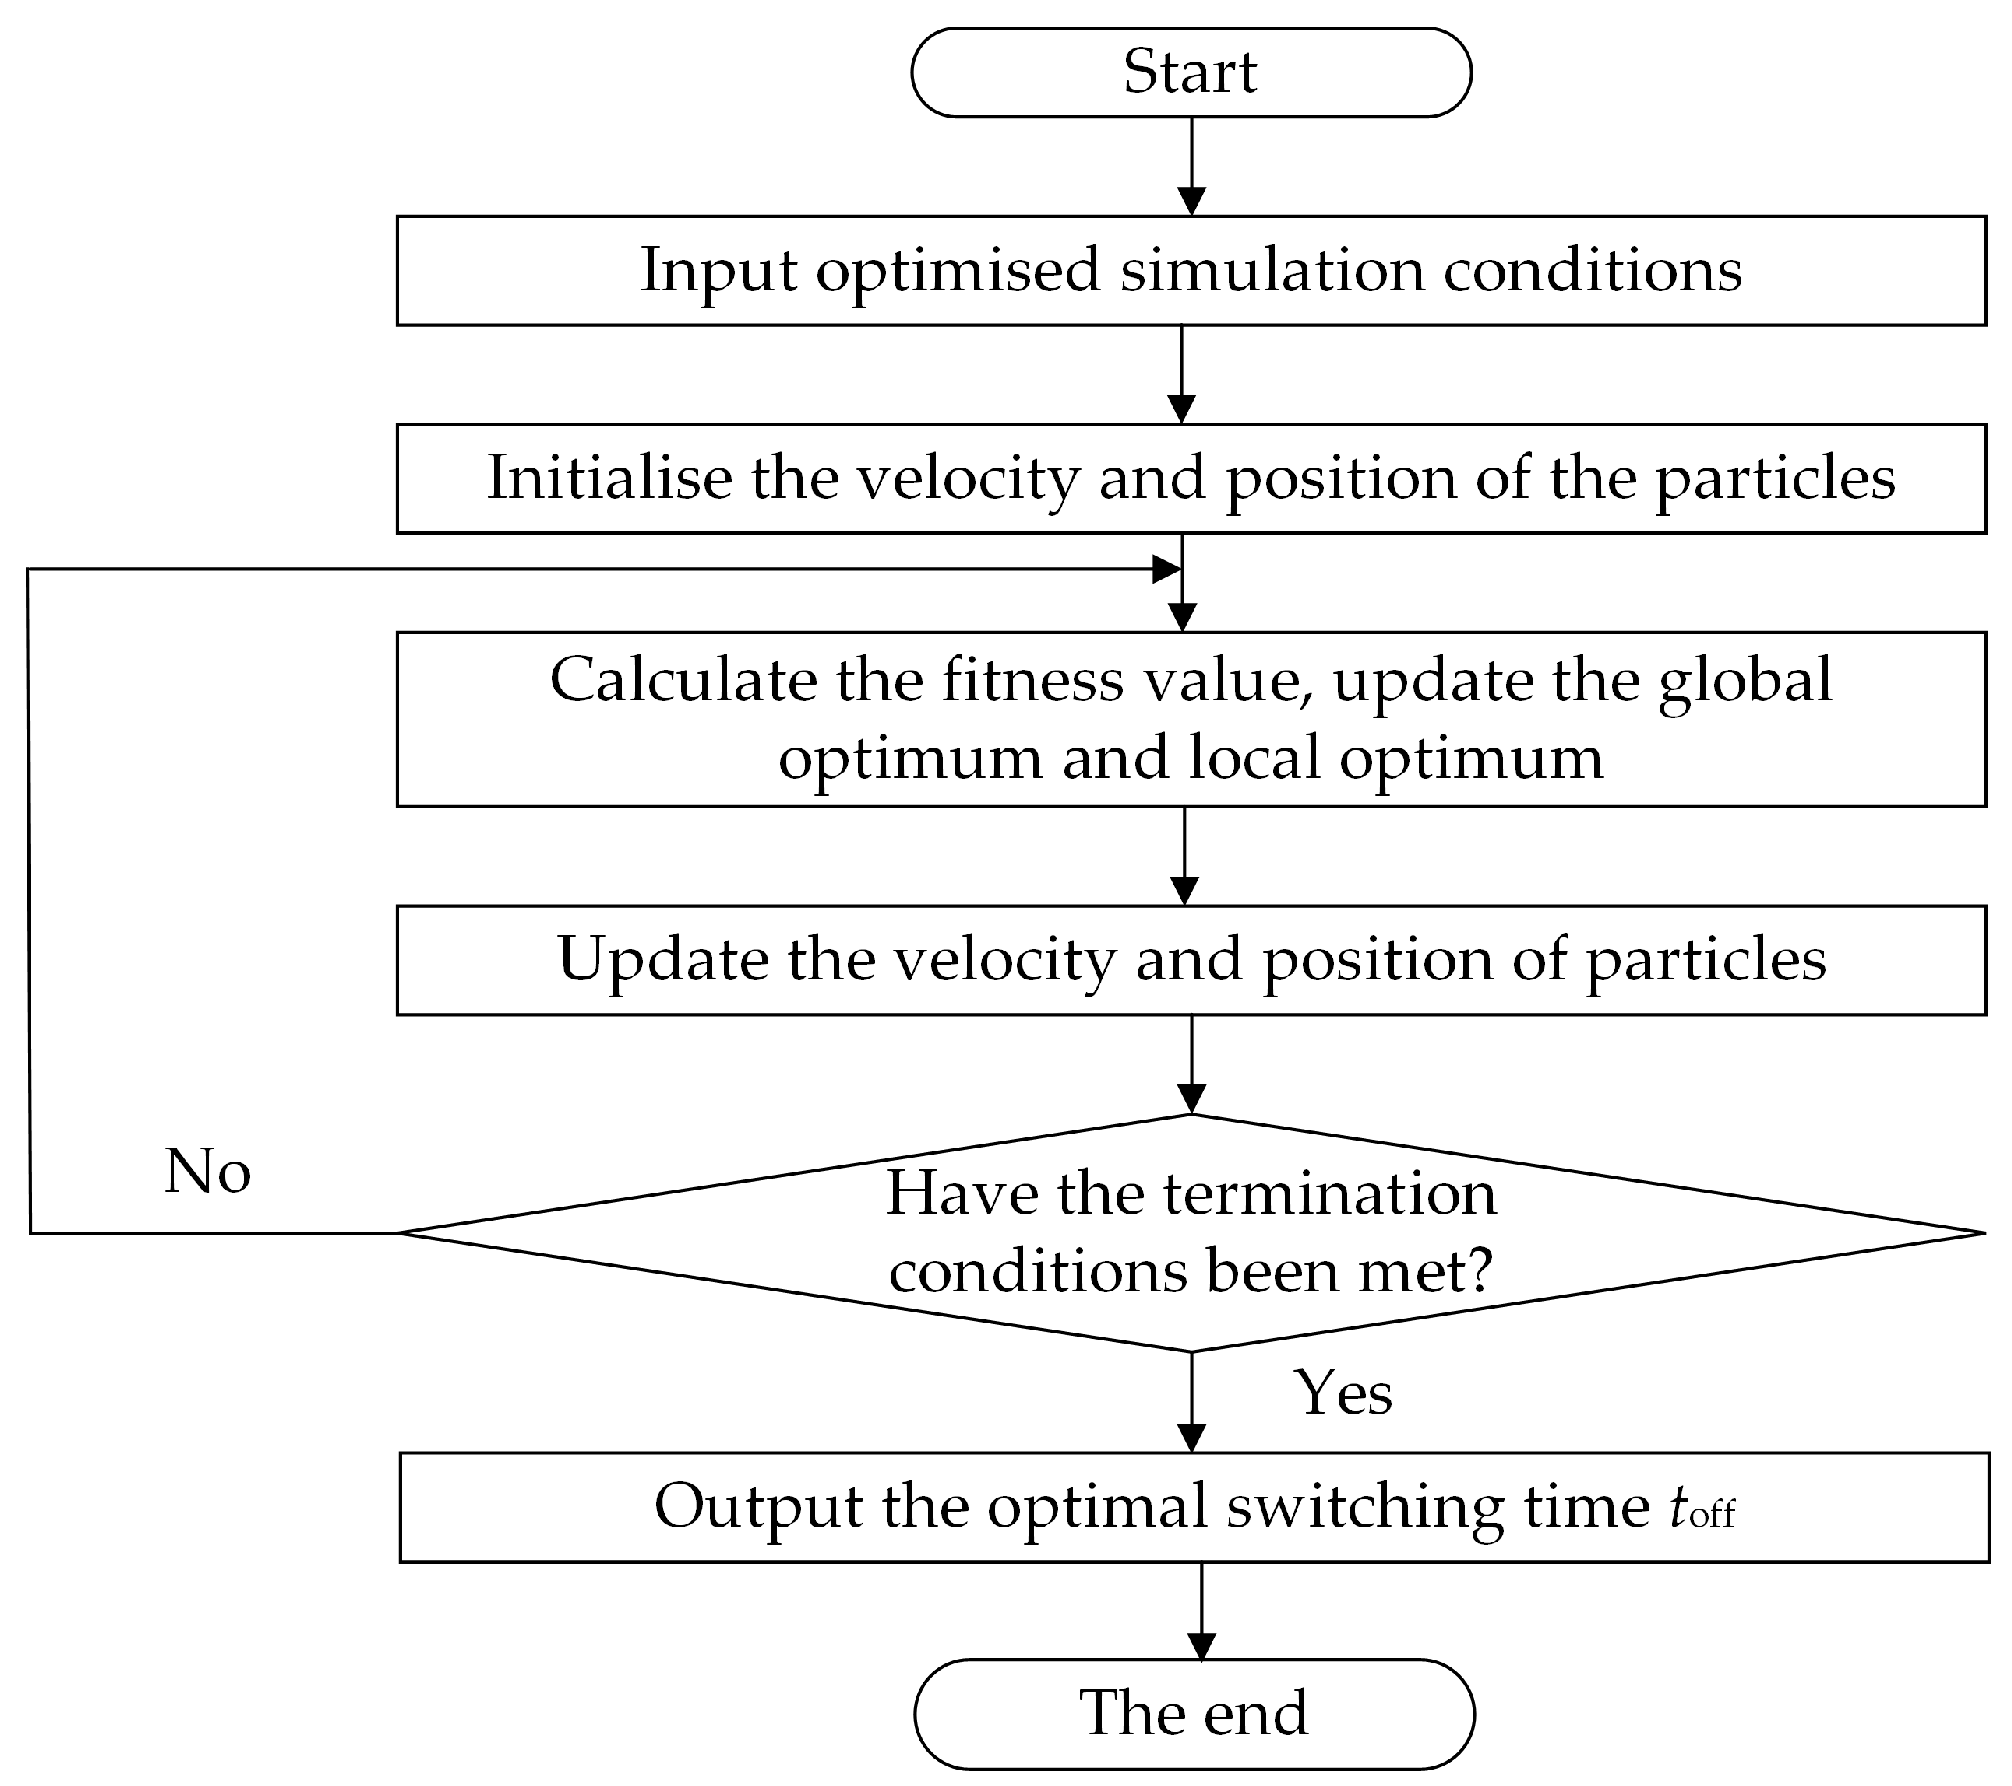
Figure 7 illustrates the process of optimizing the switching time toff using the particle swarm optimization (PSO) algorithm. Given the aggregated synchronous generator parameters, the pre-configured WT control parameters (Kd, Kp) indirectly determine toff by influencing the system’s natural frequency ωn and damping ratio ζ, thereby mitigating the severity of the SFD. It should be noted that, due to model simplifications and system parameter identification errors, the toff obtained via PSO represents an engineering-acceptable quasi-optimal solution. The practical value of this approach lies in two aspects:
Figure 7.
Flowchart for determining the optimal switching time toff using PSO.
- (1)
- Within the time window tnadir1∼tp, a monotonically correlated temporal relationship exists between system overshoot and voltage drop induced by ΔPdrop; toff tuning errors merely reduce compensation efficiency without causing mechanism failure;
- (2)
- During actual deployment, fine-tuning the toff time window by ±0.5 s enables rapid adaptation to specific site characteristics without requiring re-optimization.
3.4. Improved Fuzzy-PI Control Considering WT Operating Conditions and Speed Recovery Dynamics
The active power variation during the two-stage frequency regulation process of a WT is illustrated in Figure 1a. The kinetic energy released during the frequency support stage and absorbed during the speed recovery stage is quantified as follows:
Based on the energy conservation law, S1 equals S2. Once the FSS strategy is determined, S1 is fixed. According to (24), the design of the electromagnetic power trajectory during the SRS directly governs the recovery duration (toff to tend) and the severity of the SFD. Although traditional direct recovery strategies (e.g., stepwise) enable rapid speed recovery, they significantly exacerbate the SFD. Conversely, smooth recovery strategies mitigate the SFD but concurrently reduce the initial accelerating power, leading to prolonged operation at reduced rotor speeds.
Therefore, to achieve rapid rotor speed recovery in a WT, a step power reduction ΔPdrop is necessary to satisfy the recovery condition promptly. However, this step reduction inevitably induces SFD. To mitigate its impact, this paper coordinates the ΔPdrop application with the previously optimized toff, leveraging the system’s natural frequency overshoot to counteract the disturbance. This coordinated approach achieves an optimal trade-off between the SFD severity and the speed recovery rate.
Traditional PI controllers are employed to dynamically regulate the power reduction, with their output expressed as:
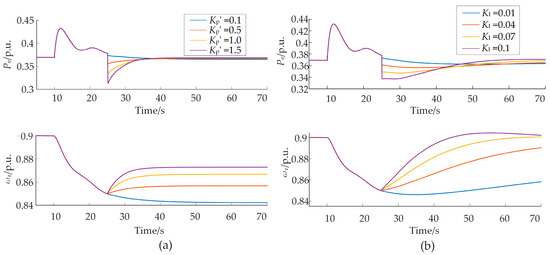
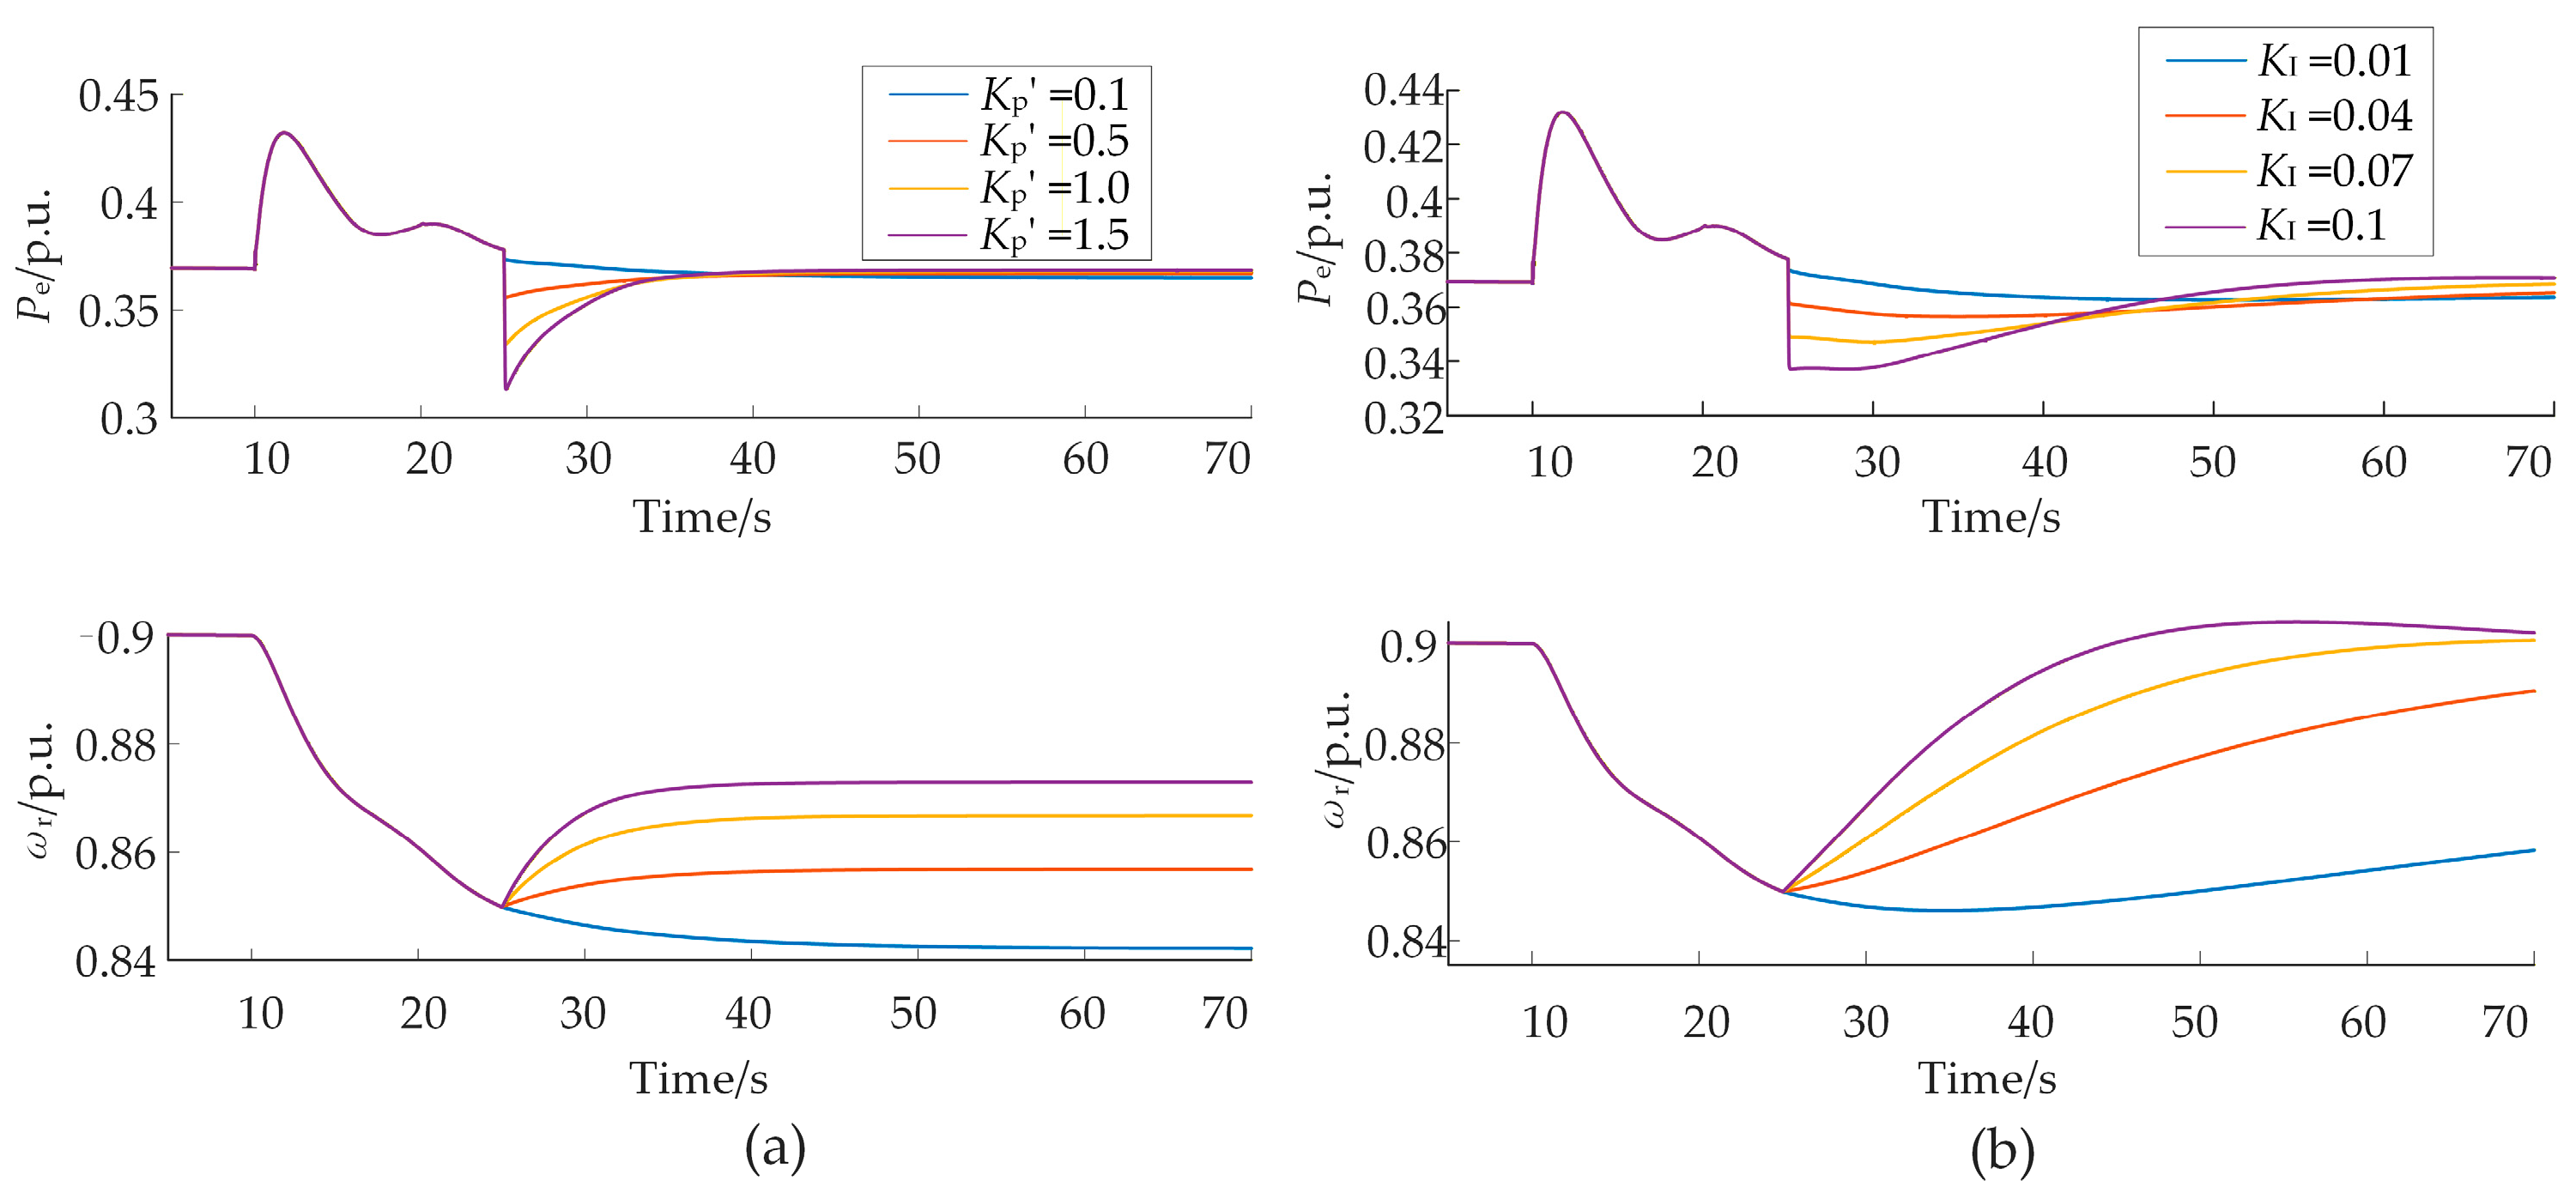
The magnitude of the instantaneous power reduction ΔPdrop depends on the rotor speed deviation and the PI controller coefficients (Kp′ and KI). The rotor speed deviation is determined by the kinetic energy released during the FSS, whereas the PI coefficients dictate the control strategy during the SRS. The influence of different PI coefficients on the WT rotor speed recovery is illustrated in Figure 8.
Figure 8.
Influence of PI controller coefficients on the speed recovery stage: (a) Impact of proportional gain Kp′ on WT power output and rotor speed; (b) Impact of integral gain KI on WT power output and rotor speed.
The rotor speed deviation (ω0 − ωoff) at toff, determined by the kinetic energy released during the FSS, is predetermined. Consequently, the selection of the PI controller coefficients (Kp’ and KI) becomes the dominant design factor. As shown in Figure 8, the proportional term (Kp’) provides an instantaneous power reduction by directly amplifying the current speed deviation. However, as the speed deviation Δω approaches zero, the proportional output diminishes to zero, thus failing to eliminate steady-state errors. The integral term (KI) accumulates past deviations, enabling continuous corrective action even when Δω is minimal. Yet, due to its inherent slow response, it provides weak initial regulation.
To address the inflexibility of fixed-gain PI controllers in dynamic conditions and enhance synergistic coordination with the preceding optimization stage, an improved fuzzy-adaptive PI controller is designed in this section. The core objective is to dynamically adjust the PI parameters (Kp’ and KI) to achieve two-stage coordination: initially prioritizing the mitigation of the SFD induced by ΔPdrop, and subsequently accelerating the rotor speed restoration to minimize energy capture losses.
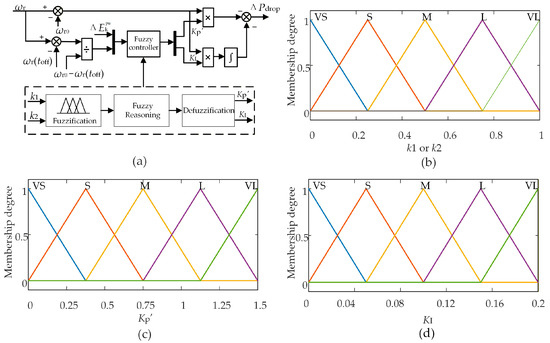
A fuzzy logic controller is selected over standard gain scheduling due to its inherent ability to handle the multi-objective, state-dependent coordination required in the SRS. While a standard gain-scheduled PI controller maps a single variable (e.g., rotor speed) to a gain, it cannot directly represent the two-dimensional trade-off between SFD mitigation and recovery acceleration. The optimal control must respond simultaneously to: (1) the turbine’s historical state, quantified by the released kinetic energy (k1), which indicates SFD risk and recovery urgency; and (2) the real-time recovery progress (k2), which determines whether the control should emphasize suppression or acceleration. Fuzzy logic excels at encoding such multi-input, multi-objective rules into linguistic expert knowledge. Its working principle is shown in Figure 9a. The following section details the selection of the input variables (k1, k2) and their role in achieving two-stage coordination.
Figure 9.
Fuzzy membership functions for the adaptive PI controller: (a) Structure of the fuzzy logic controller; (b) Membership functions for input variables k1 and k2; (c) Output membership function for proportional gain Kp’; (d) Output membership function for integral gain KI’.
(1) Selection of Fuzzy Input Variables.
Input Variable 1: normalized kinetic energy release (k1).
This variable quantifies the relative amount of rotor kinetic energy released during the frequency support stage. It indicates the WT’s operational state and remaining safety margin following the inertial response.
In this expression, ωr,cut_in denotes the WT cut-in speed, which serves as the safety lower limit for rotor operation. The magnitude of k1 directly reflects the WT’s operating state: a higher value indicates a greater rotor speed drop and a reduced stability margin. Consequently, employing excessively large PI coefficients in this state risks an overly aggressive power reduction, which could exacerbate the SFD. Conversely, a lower k1 value indicates sufficient residual kinetic energy, permitting the adoption of a more proactive recovery strategy.
Based on the aforementioned analysis, the initial value of the proportional gain Kp′ is determined according to the range of k1, as specified in Table 1. This configuration enables the controller to adapt its strategy in response to the WT’s operational state, demonstrating its inherent adaptability.
Table 1.
Initial value setting of the proportional gain Kp′ based on k1.
Furthermore, as a state variable, k1 implicitly incorporates the outcomes from the first-stage decisions, including the frequency regulation coefficients and the optimized switching time toff. As discussed in Section 2, excessive kinetic energy release and a delayed toff typically lower the rotor speed ωoff at the switching instant, thereby directly increasing k1. Consequently, an increase in the WT’s rotor speed deviation, reflected by a rise in k1, is perceived by the fuzzy controller. It then adjusts the PI coefficients to implement preemptive mitigation, achieving feedforward coordination between the two stages.
Input Variable 2: kinetic energy release rate (k2).
This variable quantifies the recovery progress from the initial speed ωoff towards the target ωr0, defined within the range [0, 1]. It is expressed as:
To achieve the time-varying control objective of “suppression first, acceleration later”, k2 provides explicit timing criteria. During the initial recovery phase (k2→0), despite significant speed deviation, overly rapid power restoration would exacerbate SFD. At this stage, the controller outputs smaller PI parameters based on the reduced k2 value, actively limiting power reduction to prioritize mitigating system impacts. During the mid-to-late recovery phase (k2→1), frequency dynamics have moderated and SFD risk diminishes. Consequently, the controller outputs larger PI parameters based on the increased k2 value, enhancing control effectiveness to rapidly eliminate speed steady-state error and expedite the wind turbine’s return to maximum wind energy tracking.
(2) Design of fuzzy output variables and rule base.
The outputs of the fuzzy controller are the PI controller gains: the proportional gain Kp′ and the integral gain KI. Based on simulation studies, the ranges for Kp′ and KI are set to [0, 1.5] and [0, 0.2], respectively.
The membership functions for the fuzzy inputs and outputs are presented in Figure 9b, Figure 9c, and Figure 9d, respectively. Both inputs and outputs are partitioned into five linguistic levels: {VS (Very Small), S (Small), M (Medium), L (Large), VL (Very Large)}. Based on the dynamic characteristics of the SRS, the fuzzy control rules are formulated as follows.
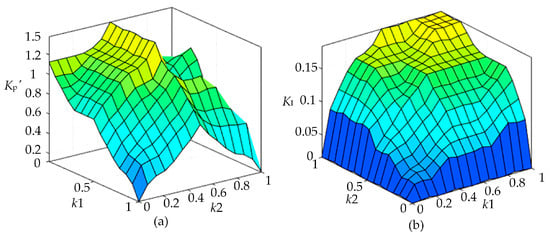
When k2 is VS, the wind turbine enters the initial recovery phase. The initial deceleration rate is adjusted by modifying Kp′ based on k1, while suppressing integral action (small KI value) to prevent overshoot. When k2 belongs to the {S, M, L} subset, the recovery phase enters the mid-stage. Increasing Kp′ and KI adjusts the acceleration zone to promote rapid speed recovery. When k2 is VL, the recovery phase enters the late stage. At this point, reducing Kp′ and increasing KI eliminates steady-state error. Based on the above reasoning principles, the fuzzy inference results are shown in Figure 10, with the specific fuzzy logic rule table presented in Table 2.
Figure 10.
Fuzzy inference results: (a) P coefficient (Kp’) Fuzzy inference result; (b) I coefficient (KI) Fuzzy inference result.
Table 2.
Fuzzy control rule base.
3.5. Integrated Two-Stage Control Strategy: Frequency Support and Rotor Speed Recovery in WT
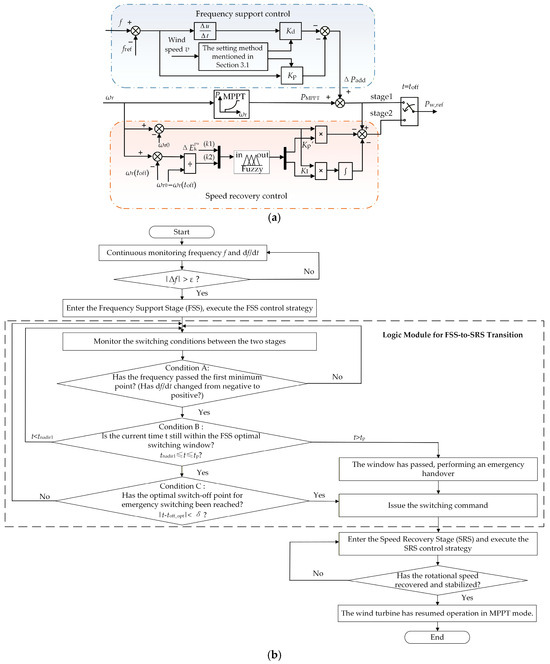
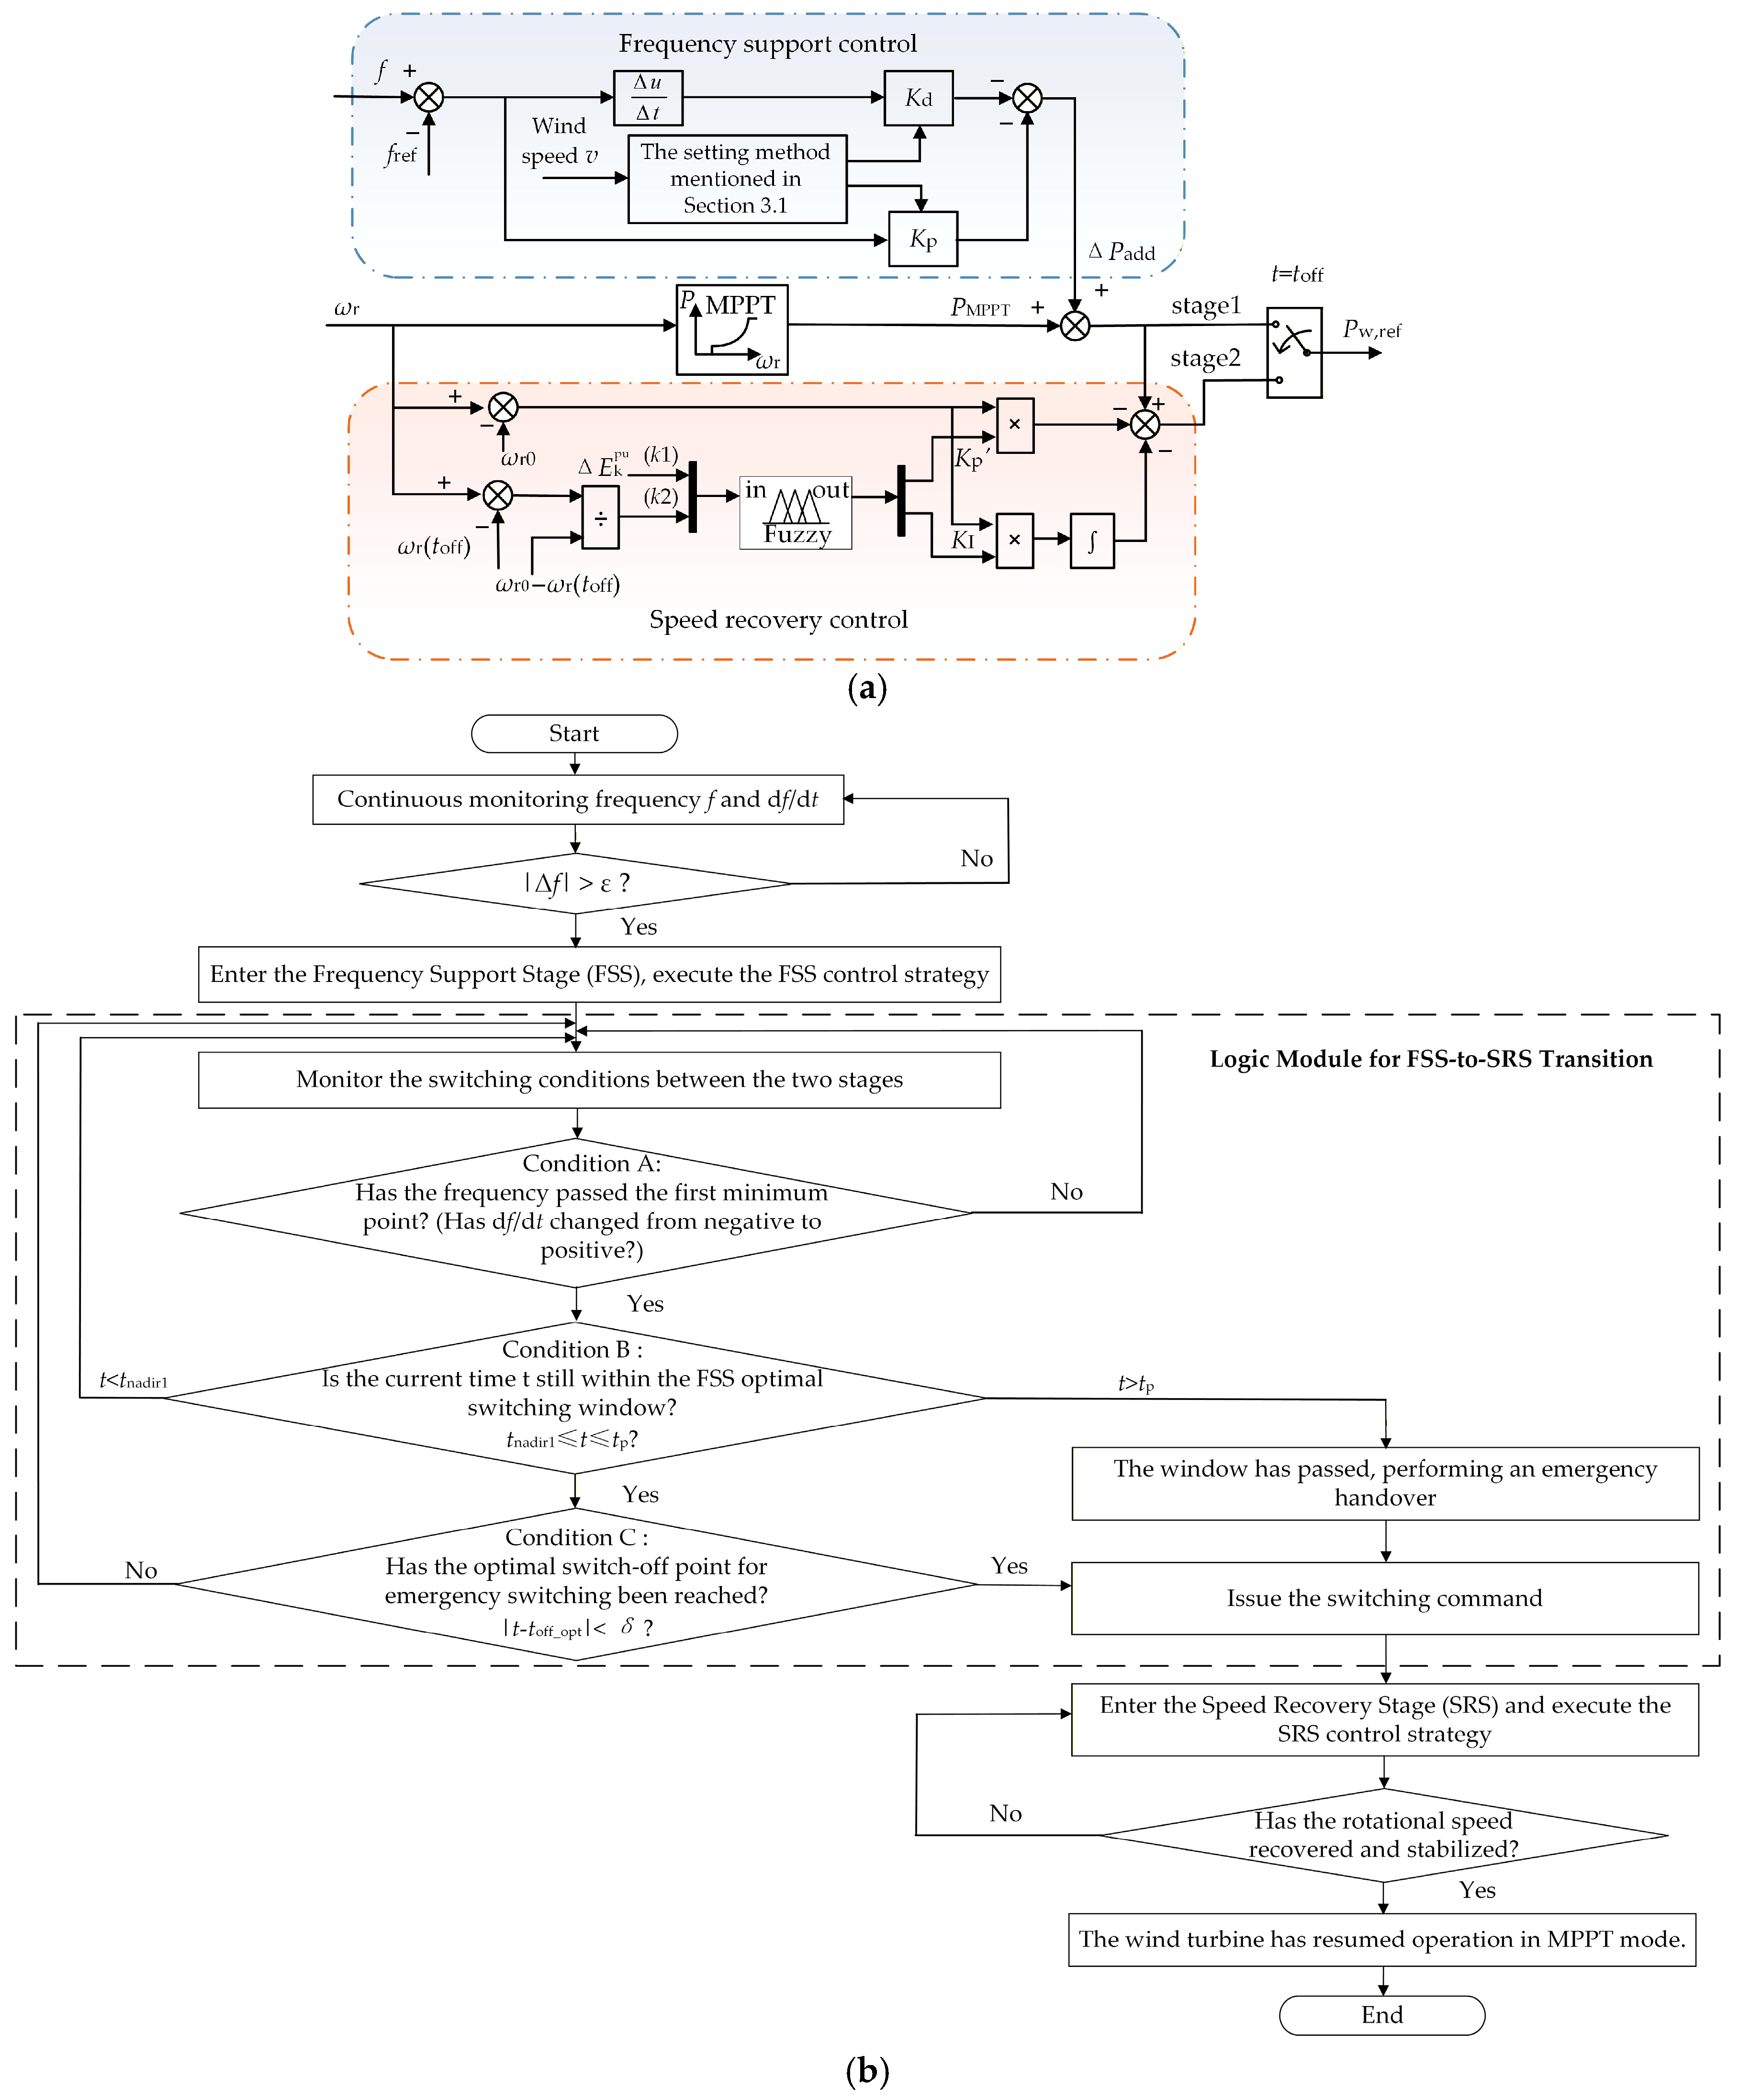
Figure 11 presents the proposed two-stage coordinated control strategy for frequency support and rotor speed recovery, along with a detailed logic flowchart depicting the transition between the two stages. The control procedure is summarized as follows:
Figure 11.
Proposed two-stage frequency regulation control strategy: (a) Schematic of the two-stage coordinated control strategy. (b) Logic flowchart for the transition from the FSS to the SRS.
During the frequency support stage, the maximum available power increment ΔPopt is calculated based on the wind speed. This is used to adaptively tune the synthetic inertia control coefficients (Kd, Kp). Subsequently, the optimal switching time toff_opt is determined based on these coefficients, triggering the transition to the speed recovery stage. In the speed recovery stage, the fuzzy logic controller calculates dynamic adjustment factors. Based on the inputs k1 and k2, the PI controller parameters (Kp′, KI) are updated in real time, thereby dynamically adjusting the power reduction ΔPdrop(t). This coordinated action effectively suppresses the SFD while accelerating the rotor speed recovery.
4. Case Studies
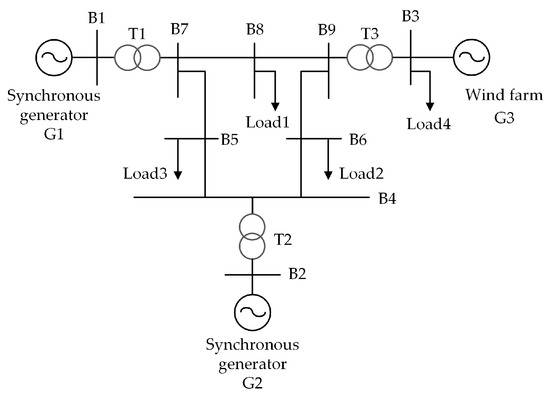
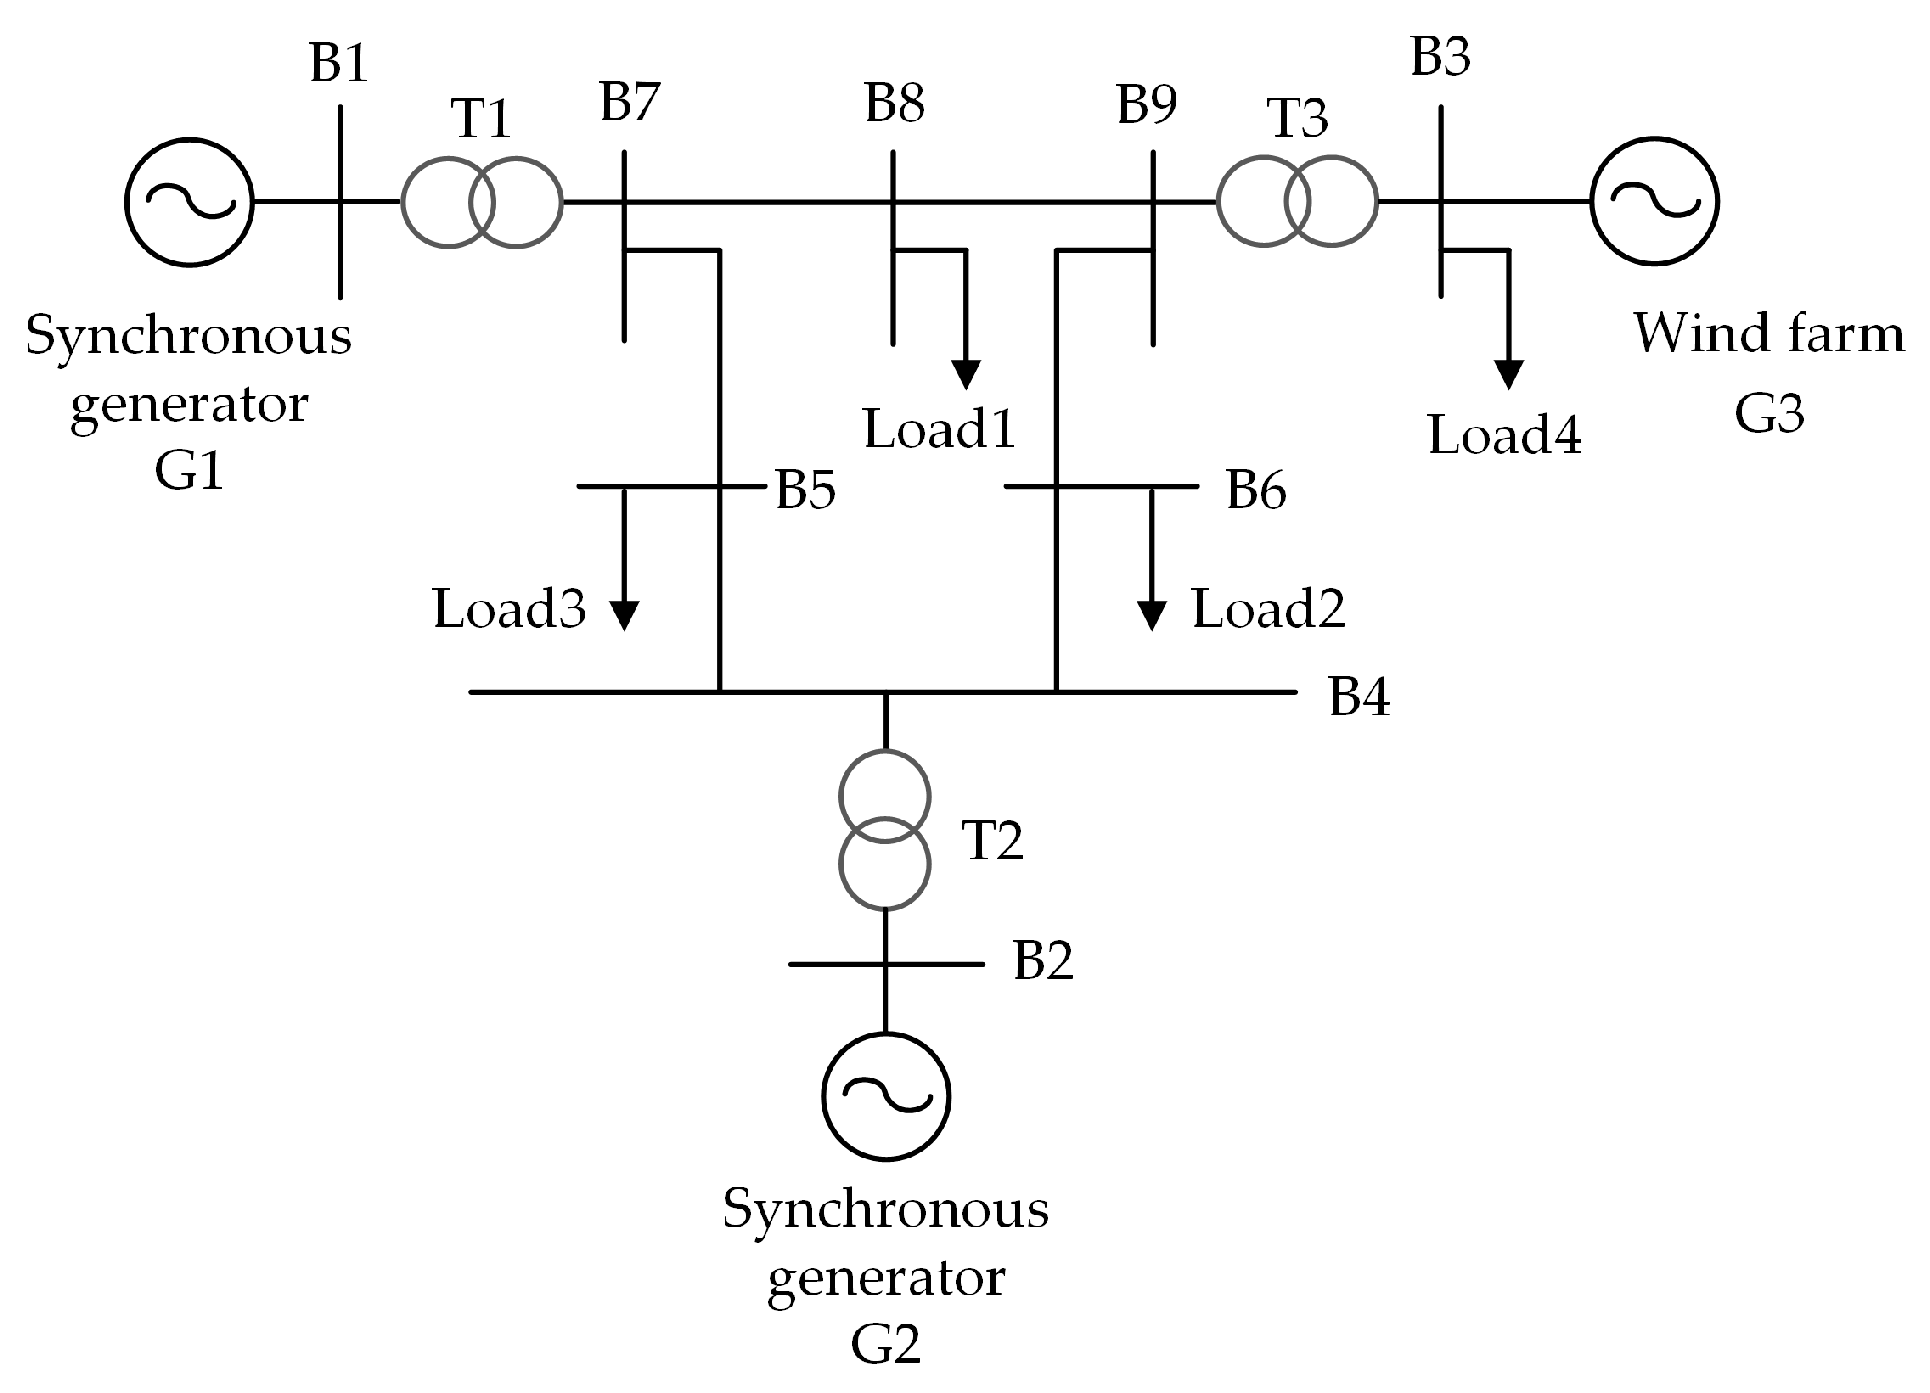
To validate the proposed two-stage coordinated frequency regulation strategy for WTs, a three-machine, nine-bus power system model with integrated wind power is established on the MATLAB/Simulink (R2023a) platform, as shown in Figure 12. The system includes two synchronous generators (G1, G2) and an equivalent wind power plant, which aggregates 35 doubly fed induction generator (DFIG)-based WTs, each rated at 1.5 MW, resulting in a wind power penetration level of 20.8%. The detailed parameters of the units are provided in Table 3. During the simulation, a sudden increase of 35 MW is applied to Load 3 at t = 20 s. The total simulation time is 80 s.
Figure 12.
Schematic of the three-machine, nine-bus power system simulation model.
Table 3.
Key Parameters of the power system.
To compare the performance of different frequency control strategies across varying wind speeds, four case studies are established:
Case 1 (Baseline): The WT operates solely in maximum power point tracking mode without providing frequency response.
Case 2 (Conventional): The WT employs conventional synthetic inertia control (fixed coefficients) during the FSS and reverts to MPPT during the SRS.
Case 3 (Ref. [20]): The WT employs the two-stage control from [20], featuring variable-coefficient control during FSS and variable-coefficient PI control triggered at the rotor speed nadir for SRS.
Case 4 (Proposed): The WT adopts the proposed two-stage strategy. The frequency regulation coefficients are adaptively tuned based on operating conditions, and the optimal switching time toff is determined accordingly. Subsequently, the adaptive fuzzy-PI control is activated during SRS.
To validate the superiority of the control strategy proposed in Section 3 in achieving multi-objective coordination—namely, initial frequency drop suppression, SFD mitigation, and rapid rotor speed recovery—simulations of Cases 1 to 4 were conducted under the wind speed scenarios outlined in Section 4.1 and Section 4.2. A comparative analysis of the control performance among the four methods was then performed.
4.1. Case Study Under Rated Wind Speed (9 m/s)
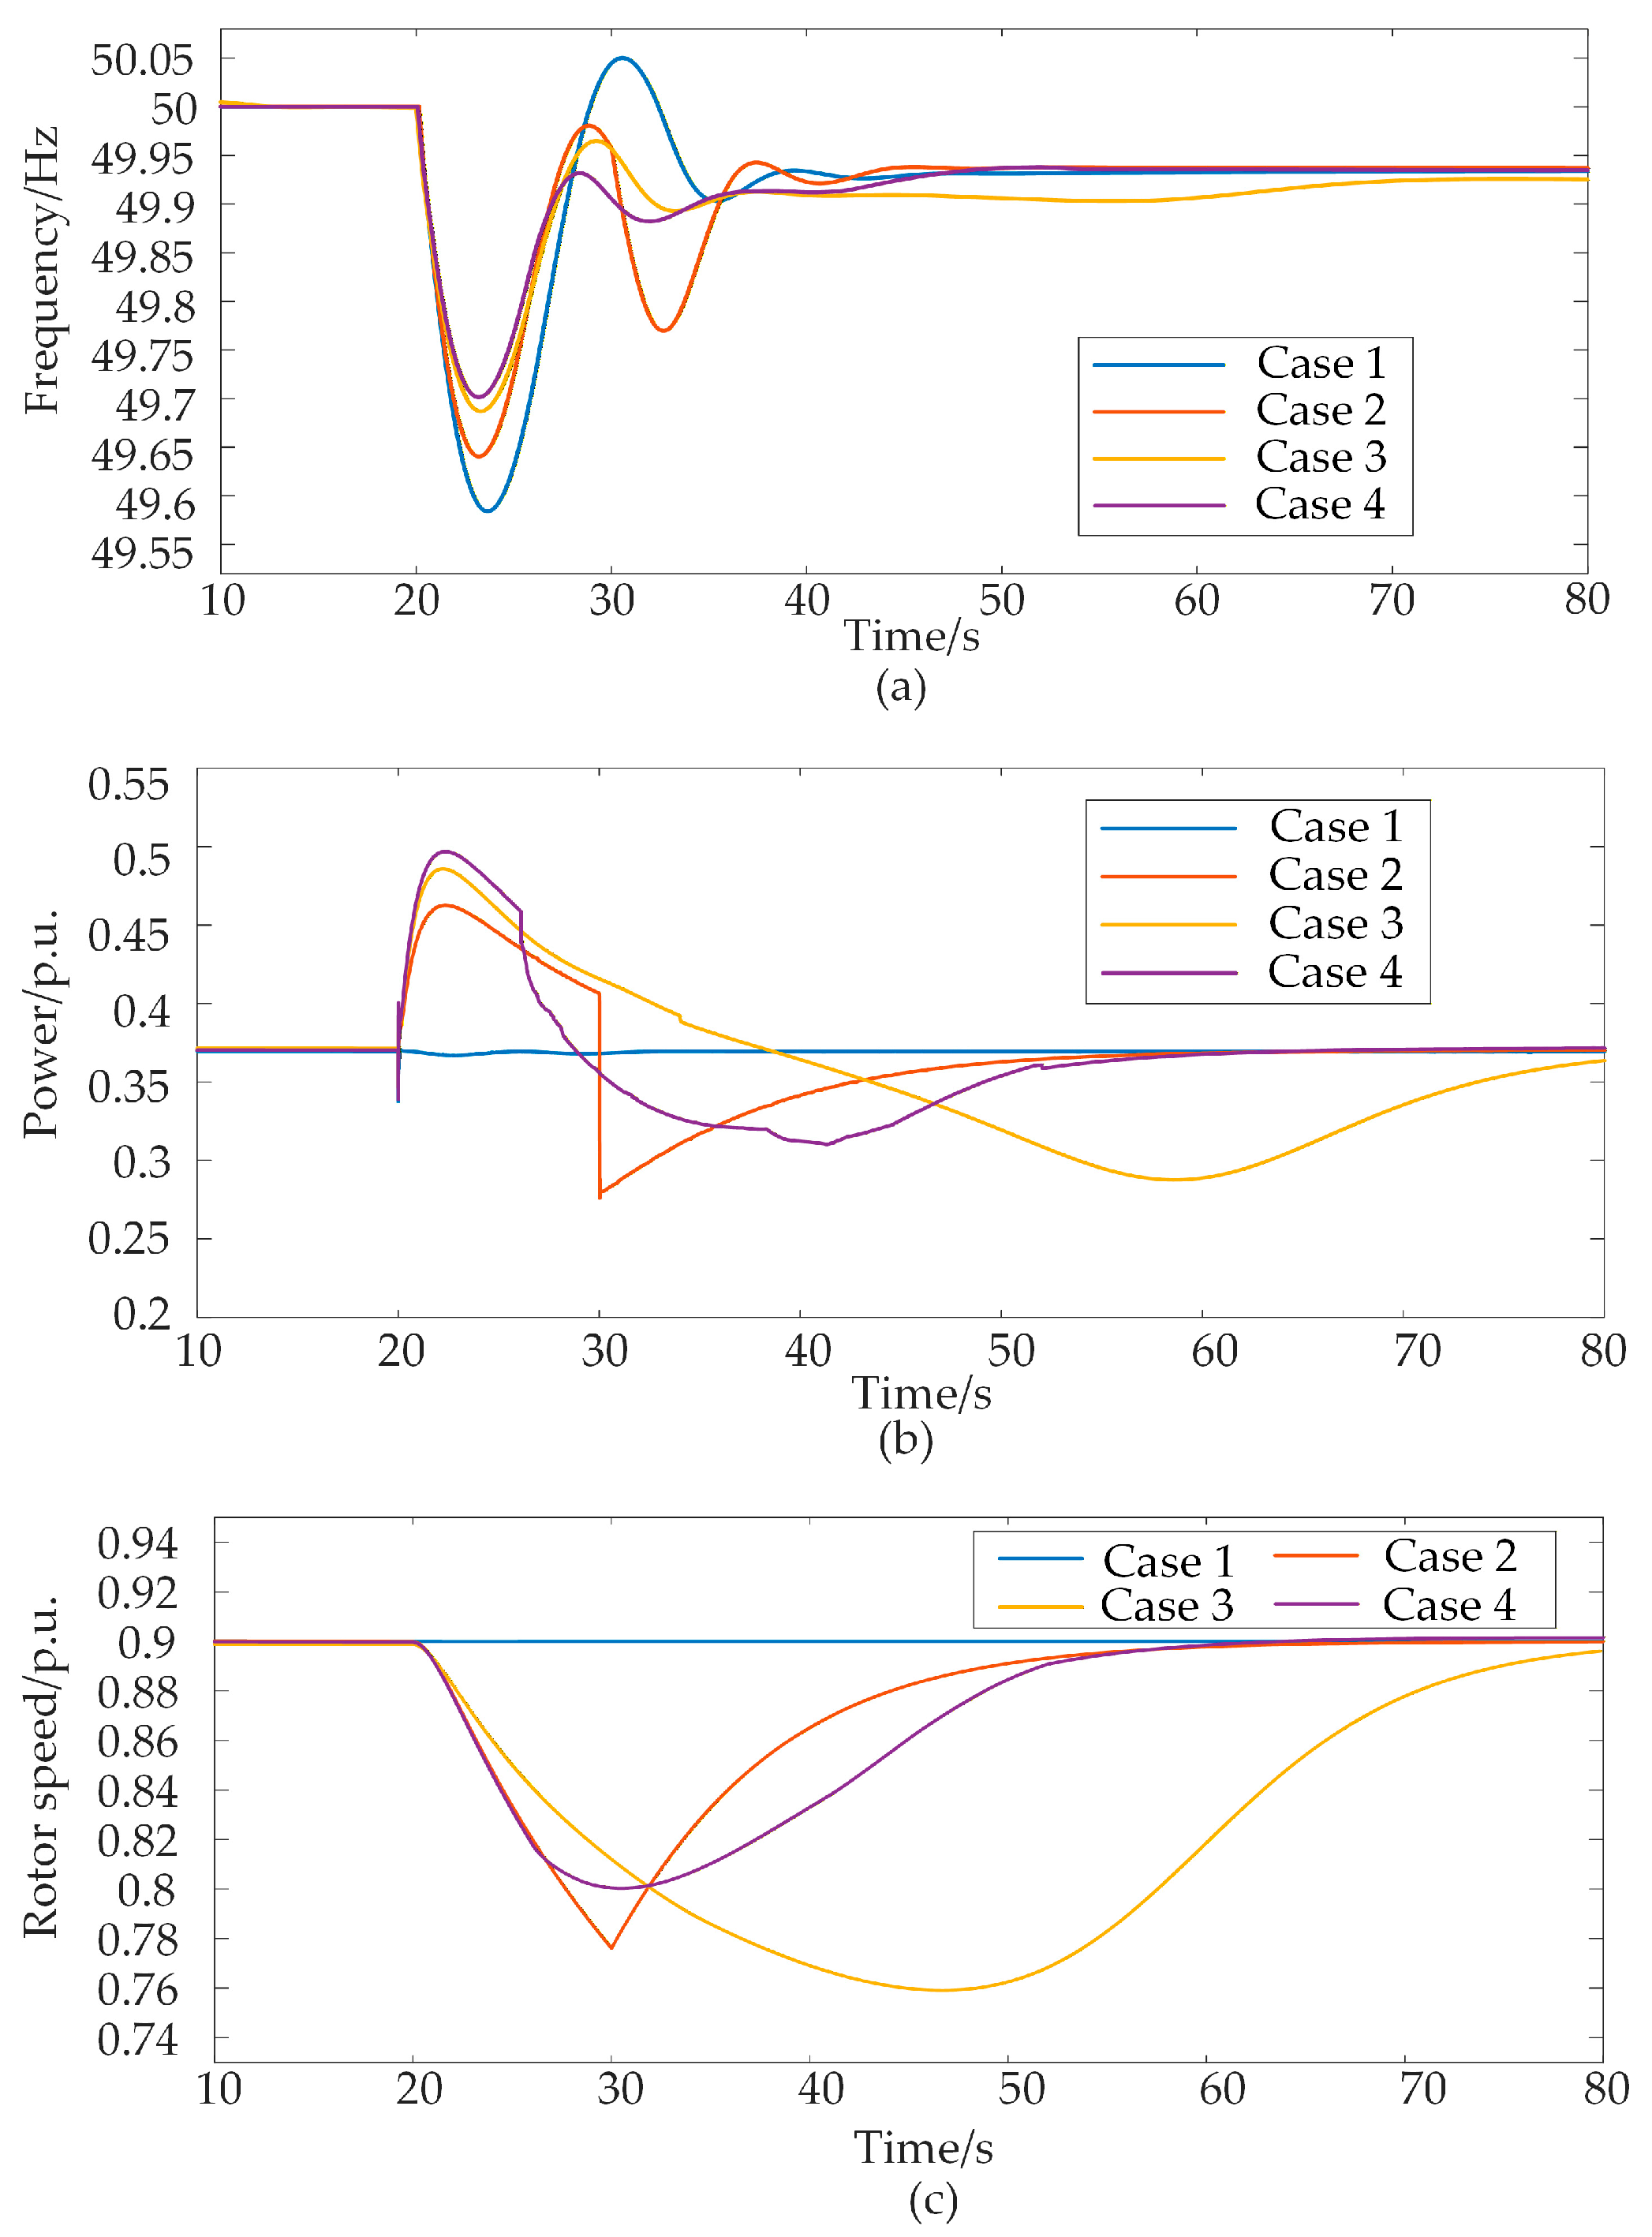
The initial wind speed for the WT is set to 9 m/s. To simulate a sudden frequency drop, a load increase of 35 MW is applied at t = 20 s. The identified system inherent parameters and the tuned frequency regulation coefficients (Kd = 28, Kp = 4.8) are input into the optimization algorithm, yielding an optimal switching time of toff = 26.3 s. For comparison, the system frequency response is also evaluated for the conventional strategy and the strategy from [20], both using an empirical switching time of toff = 30 s. The simulation results are presented in Figure 13.
Figure 13.
Simulation results for Case Study 1 (9 m/s): (a) System frequency; (b) Active power of the WT; (c) Rotor speed of the WT.
A comparison of the simulation results reveals that under the 9 m/s wind condition, the WT in Case 1 (Baseline) operates purely in MPPT mode, maintaining a constant rotor speed of 0.9 p.u. Due to its inability to provide inertial response or frequency support, it experiences the most severe frequency drop, with a nadir of 49.572 Hz. Cases 2 through 4 employ additional control strategies, sequentially raising the frequency nadir to 49.638 Hz, 49.682 Hz, and 49.704 Hz, respectively. Among them, Case 4 (Proposed), benefiting from the improved synthetic inertia control, dynamically adjusts the power increment for inertia response based on wind speed and load conditions. This results in significantly superior frequency support performance compared to Case 2 (Conventional) with fixed control coefficients.
Upon entering the SRS, Case 2 (Conventional) employs a stepwise power reduction strategy, switching to MPPT mode for recovery. Although this strategy enables rapid recovery, the significant power step induces a secondary frequency drop to 49.769 Hz, which is a notable drawback. In contrast, Case 3 (Ref. [20]) and Case 4 (Proposed) effectively mitigate the SFD via variable-coefficient PI control and adaptive fuzzy-PI control, respectively. However, both strategies exhibit frequency oscillations due to system overshoot, raising their respective SFD nadirs to 49.891 Hz and 49.875 Hz.
Further analysis indicates that while the PI control in Case 3 (Ref. [20]) effectively mitigates SFD, it requires the rotor speed to reach its nadir before initiating the recovery strategy. This results in a prolonged recovery time exceeding 80 s, failing to meet the requirement for rapid restoration. Simultaneously, after the frequency reaches its first nadir, the task of the WT’s frequency support stage is completed. However, the continued release of rotor kinetic energy causes a significant further drop in rotor speed. This not only wastes kinetic energy but also prolongs the time required to recover to the initial speed. In contrast, the adaptive fuzzy-PI control in Case 4 (Proposed) dynamically adjusts the control parameters based on the kinetic energy released during the FSS and the speed deviation during the SRS. This significantly accelerates the rotor speed recovery, completing it in only 62.395 s. Moreover, Case 4 optimizes the switching time between the two stages. This allows the overshoot component from the FSS to partially offset the SFD induced by the power reduction in the SRS. Consequently, it achieves superior coordination between frequency support and speed recovery, demonstrating the most optimal overall performance.
4.2. Case Study Under High Wind Speed (11 m/s)
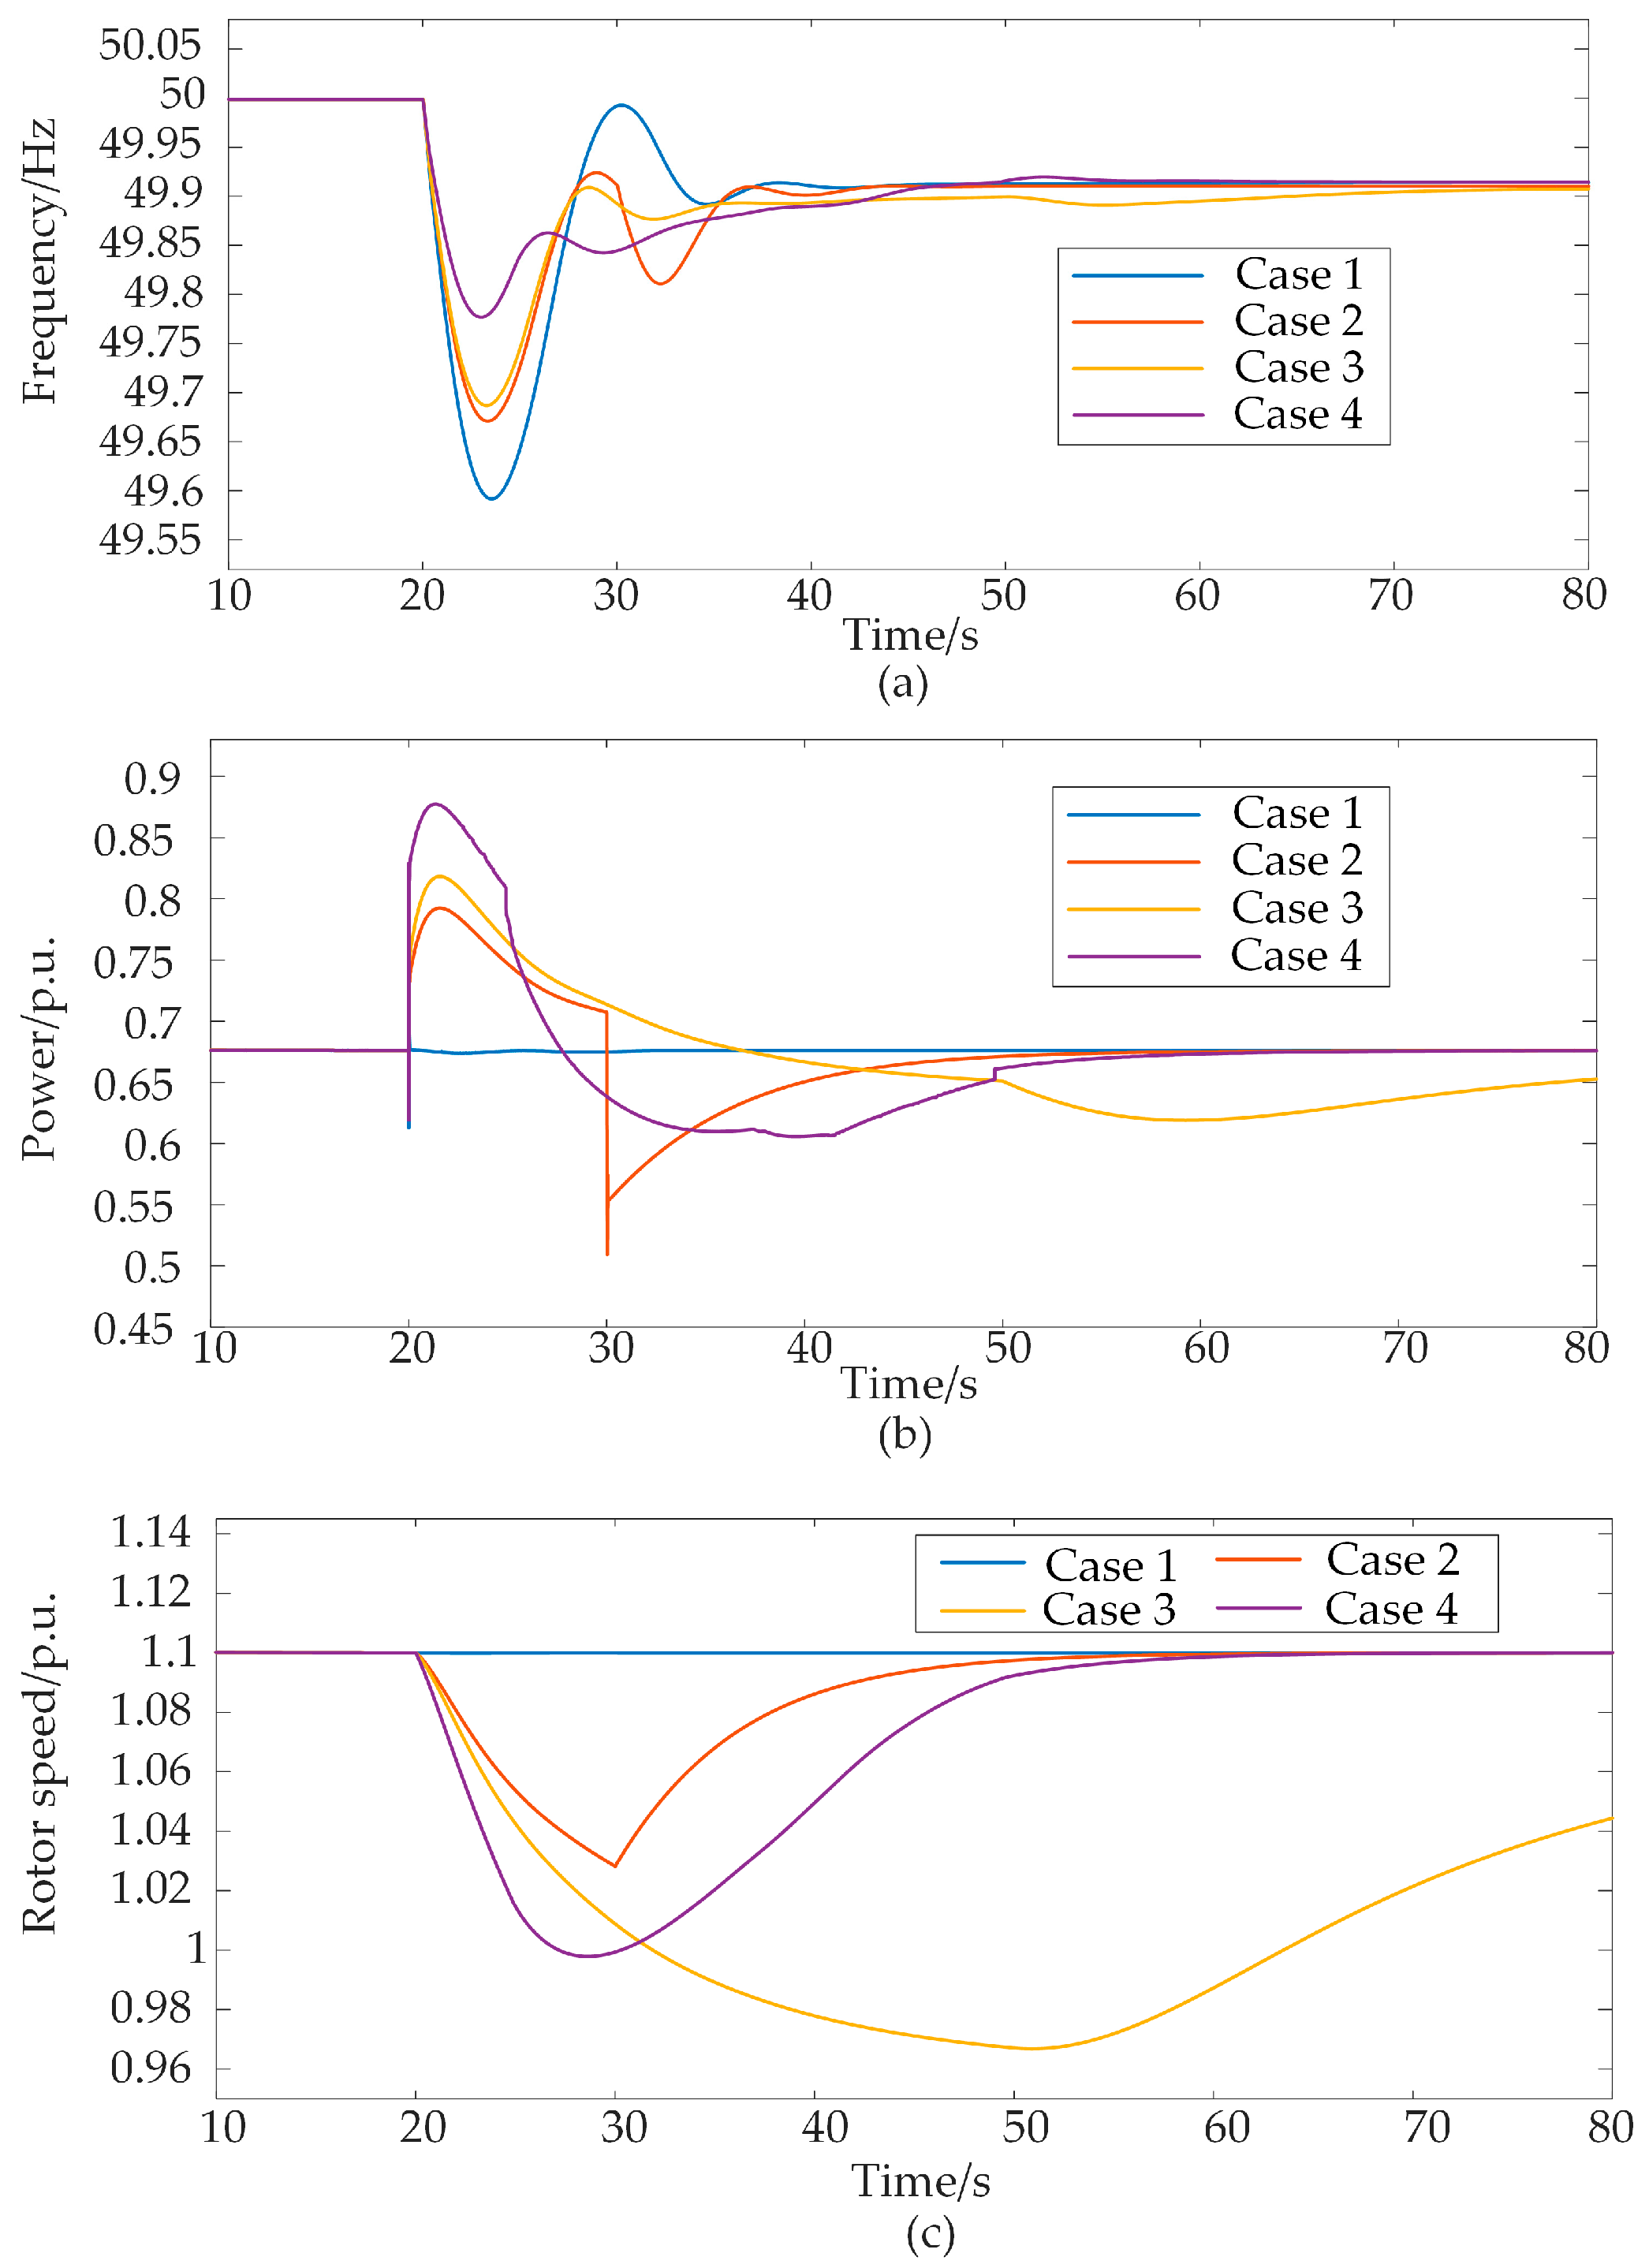
In Case Study 2, the initial wind speed for the WT is set to 11 m/s. To simulate a sudden frequency drop, a load increase of 35 MW is applied at t = 20 s. The identified system inherent parameters and the tuned frequency regulation coefficients (Kd = 43.75, Kp = 7.5) are input into the optimization algorithm, yielding an optimal switching time of toff = 25.4 s. For comparison, the system frequency response under the conventional strategy (using an empirical toff = 30 s) is also evaluated alongside that of the strategy from [20]. The simulation results are presented in Figure 14.
Figure 14.
Simulation results for Case Study 2 (11 m/s): (a) System frequency; (b) Active power of the WT; (c) Rotor speed of the WT.
The simulation results show that under the 11 m/s wind condition, the WT in Case 1 (Baseline) does not participate in frequency regulation. Consequently, its rotor speed remains constant at 1.1 p.u., and it fails to provide power support following the disturbance, resulting in the most severe frequency drop, with a nadir of 49.578 Hz. As analyzed earlier, during the FSS, the available power increment of the WT is higher under the 11 m/s condition. Case 4 (Proposed) employs the proposed coordinated control strategy. By optimizing the kinetic energy release during the FSS, it elevates the frequency nadir to 49.775 Hz. This represents improvements of 0.107 Hz and 0.089 Hz over the conventional fixed-parameter control in Case 2 (49.668 Hz) and the strategy in Case 3 (49.686 Hz), respectively. This result validates the significant effectiveness of the proposed method in mitigating the initial frequency dip.
Additionally, Case 4 employs an adaptive switching time toff determined by the frequency regulation parameters. This enables the overshoot component from the FSS to effectively offset the dip component induced by the power reduction in the SRS. Simultaneously, it dynamically adjusts the PI parameters based on the kinetic energy released during the FSS. This ensures optimal coordination between the objective of elevating the frequency nadir in the FSS and the goal of achieving rapid rotor speed recovery in the SRS. Consequently, The proposed strategy effectively suppresses the SFD caused by power transients. In Case 4, the secondary frequency nadir is 49.838 Hz, which is 0.027 Hz higher than that in Case 2. Furthermore, this strategy significantly reduces the rotor speed recovery time to 56.806 s, demonstrating markedly better performance than Case 3. These results fully validate the overall effectiveness of the proposed method, both in mitigating the primary and secondary frequency dips and in accelerating the rotor speed recovery.
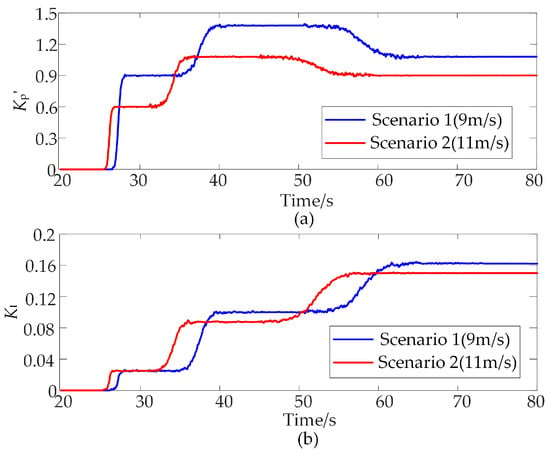
The aforementioned simulation results demonstrate that the proposed strategy (Case 4) exhibits superior comprehensive performance in both frequency support and speed recovery compared to the reference cases. To further elucidate the underlying mechanism, the dynamic variations in the internal controller parameters, Kp′ and KI, for the two case studies are extracted and presented in Figure 15. An analysis based on these results is then provided.
Figure 15.
Adaptive adjustment process of the fuzzy-PI controller parameters: (a) Proportional gain Kp′; (b) Integral gain KI.
The simulation results show that at the switching instant toff, the controller initiates rapidly. This achieves a “feedforward sensing and initial suppression” effect. The initial values of Kp′ and KI for Case Study 2 (11 m/s) are significantly lower than those for Case Study 1 (9 m/s). This is because, at the higher wind speed, more kinetic energy is released during the FSS, corresponding to a larger k1 value. Based on the fuzzy rules, the controller automatically adopts a more conservative initial parameter set to constrain the rate of power change during the SRS. This action suppresses the effects of the increased kinetic energy release during the FSS and mitigates potential high-power impacts resulting from the toff decision, thereby effectively preventing a severe SFD.
Concurrently, as the recovery progresses (indicated by an increasing k2), the parameters are smoothly adjusted to enhance the regulatory capability, thereby achieving rapid recovery while avoiding overshoot and oscillation. During the later stages of recovery, the controller demonstrates intelligent trade-off capability: Kp′is appropriately moderated while KI continues to accumulate towards its maximum, precisely implementing the “late-stage reduction in the proportional term and increase in the integral term” rule for steady-state error elimination. This dynamic optimization ensures that the rotor speed converges to the target without steady-state error, while circumventing the inherent risks of overshoot and oscillation associated with fixed-gain PI controllers.
The presented case study under constant wind speed establishes a clear performance baseline for the coordinated architecture. It is noteworthy that the state-feedback nature of the controller (via k1, k2) provides inherent adaptability to wind speed variations. Preliminary testing under varying wind conditions confirms that the strategy’s performance ranking and key advantages are maintained, further solidifying its robustness. A comprehensive statistical evaluation under full turbulence wind spectra is a primary focus for future work.
Analysis of the comprehensive simulation results demonstrates that the proposed coordinated control strategy achieves an overall enhancement in frequency regulation performance. By adaptively tuning the frequency regulation coefficients based on the available kinetic energy under varying wind speeds, the strategy fully exploits the frequency support potential of the WT. The two-stage switching time is optimized based on the frequency regulation coefficients to mitigate the SFD. Through the adaptive fuzzy-PI control mechanism, it accelerates rotor speed recovery while ensuring system frequency stability. The superior performance stems from a two-layer coordination that actively navigates the inherent Pareto-optimal frontier between SFD mitigation and recovery speed. First, the optimized switching time (toff) shifts the performance frontier itself, expanding the envelope of achievable outcomes. Second, the fuzzy-PI controller dynamically selects the optimal operating point on this frontier in real time by balancing the historical energy release (k1) against the instantaneous recovery progress (k2). This state-dependent adaptation, rather than a fixed compromise, ensures a optimal response that aligns grid support needs with turbine recovery throughout the frequency event. The simulation results confirm that the proposed method effectively coordinates the frequency regulation demands with the operational constraints across diverse operating conditions. Its characteristics of “rapid response, smooth transition, and sustainable support” align more closely with the stringent frequency control requirements of future power systems with high renewable penetration.
5. Conclusions
This paper proposes a two-stage coordinated frequency regulation strategy for WTs. This strategy simultaneously addresses three post-disturbance issues: initial frequency drop mitigation, secondary frequency drop suppression, and rotor speed recovery. It is designed according to the distinct frequency response characteristics of each stage.
Simulation case studies at wind speeds of 9 m/s and 11 m/s provide quantitative validation. Compared to the no-frequency-control baseline (Case 1), the proposed strategy (Case 4) raises the primary frequency nadir by up to 0.197 Hz. Compared to the conventional fixed-parameter control with stepwise recovery (Case 2), it reduces the secondary frequency drop by 0.106 Hz and accelerates rotor speed recovery by over 30%. Furthermore, compared to the advanced two-stage method in [20] (Case 3), which requires over 80 s for recovery, the proposed strategy achieves full recovery within 56.8–62.4 s while maintaining comparable or better frequency stability. These comparative results clearly demonstrate the strategy’s effectiveness in coordinating conflicting objectives.
Based on this study, the following key conclusions are drawn:
- (1)
- The severity of the secondary frequency drop is closely related to the two-stage switching time, the control strategy during the frequency support stage, and the recovery strategy during the speed recovery stage. By appropriately selecting the switching time and utilizing the disturbance overshoot component from the FSS to offset the frequency dip induced by the power reduction in the SRS, the SFD can be effectively mitigated.
- (2)
- This study integrates fuzzy logic with PI control. During the frequency support stage, the frequency regulation coefficients are adaptively tuned according to the wind speed to optimize the power support capability. In the SRS, dynamic adjustment of the PI parameters enables coordinated control to suppress the SFD while achieving rapid rotor speed recovery. This approach significantly accelerates the WT’s rotor speed recovery, reduces the duration of derated operation, and enhances both its power generation efficiency and subsequent frequency regulation capability.
In summary, the proposed two-stage coordination framework is fundamentally designed to manage the temporal and dynamic trade-off between frequency support and rotor state recovery. Although this study focuses on its implementation and validation for wind turbines with synthetic inertia, the core coordination principle is inherently adaptable. For instance, in a deloaded operation mode, the strategy would operate in a simplified form, wherein the designed fuzzy controller remains effective in maintaining system dynamic stability by managing the withdrawal of power reserves.
Building upon the foundations laid in this study, future work will focus on three key extensions to enhance the robustness and practical applicability of the proposed strategy. First, the control framework will be integrated with a high-fidelity mechanical model to enable detailed analysis of transient torque oscillations and drivetrain stresses during the rapid recovery phase, thereby ensuring structural feasibility. Second, more accurate and generalized methods for determining the optimal switching time will be developed to accommodate a wider range of wind turbine control architectures. Finally, a comprehensive performance evaluation under full turbulence wind spectra will be conducted, along with further investigation into the mechanical dynamics during recovery, to systematically validate and refine the coordination of the two-stage control approach.
Author Contributions
Conceptualization, Y.H. and Y.Z.; methodology, Y.H.; software, Y.Z.; validation, Y.H. and K.L.; formal analysis, Y.H.; investigation, Y.H.; resources, Y.Z.; data curation, K.L.; writing—original draft preparation, Y.H.; writing—review and editing, Y.H.; visualization, K.L.; supervision, Y.H.; project administration, K.L. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| WT | Wind turbine |
| SFD | Secondary frequency drop |
| FSS | Frequency support stage |
| SRS | Speed recovery stage |
| ST | Stepwise |
| PFD | Primary frequency drop |
| DFIG | Doubly fed induction generator |
| MPPT | Maximum power point tracking |
| ROCOF | Rate of change of frequency |
| SG | Synchronous generator |
| H | Inertia constant |
| R | Governor speed regulation |
| D | Load damping factor |
| Km | Constant gain |
| FH | High-pressure turbine fraction |
| TR | Reheat time constant |
| γ | Wind power penetration rate |
| PSO | Particle swarm optimization |
References
- Zhuo, Z.; Du, E.; Zhang, N.; Nielsen, C.P.; Lu, X.; Xiao, J.; Wu, J.; Kang, C. Cost Increase in the Electricity Supply to Achieve Carbon Neutrality in China. Nat. Commun. 2022, 13, 3172. [Google Scholar] [CrossRef] [Scilit]
- Zhang, G.; Zhang, F.; Ding, L.; Meng, K.; Dong, Z.Y. Wind Farm Level Coordination for Optimal Inertial Control with a Second-Order Cone Predictive Model. IEEE Trans. Sustain. Energy 2021, 12, 2353–2366. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z.; Liu, J.; Guo, L.; Li, X.; Liu, Y.; Wang, C. Towards wind farm droop-inertia feasible region assessment: A state space transformation approach considering power system dynamics. Sustain. Energy Technol. Assess. 2024, 71, 103961. [Google Scholar] [CrossRef] [Scilit]
- Fu, Y.; Zhang, X.; Hei, Y.; Wang, H. Active Participation of Variable Speed Wind Turbine in Inertial and Primary Frequency Regulations. Electr. Power Syst. Res. 2017, 147, 174–184. [Google Scholar] [CrossRef] [Scilit]
- Peng, X.; Yao, W.; Yan, C.; Wen, J.; Cheng, S. Two-Stage Variable Proportion Coefficient Based Frequency Support of Grid-Connected DFIG-WTs. IEEE Trans. Power Syst. 2020, 35, 962–974. [Google Scholar] [CrossRef] [Scilit]
- Badesa, L.; Teng, F.; Strbac, G. Conditions for Regional Frequency Stability in Power System Scheduling—Part I: Theory. IEEE Trans. Power Syst. 2021, 36, 5558–5566. [Google Scholar] [CrossRef] [Scilit]
- Gao, X.; Wang, Z.; Ding, L.; Bao, W.; Wang, Z.; Hao, Q. A novel virtual synchronous generator control scheme of DFIG-based wind turbine generators based on the rotor current-induced electromotive force. Int. J. Electr. Power Energy Syst. 2024, 156, 109688. [Google Scholar] [CrossRef] [Scilit]
- Bao, W.; Ding, L.; Liu, Z.; Zhu, G.; Kheshti, M.; Wu, Q.; Terzija, V. Analytically Derived Fixed Termination Time for Stepwise Inertial Control of Wind Turbines—Part I: Analytical Derivation. Int. J. Electr. Power Energy Syst. 2020, 121, 106120. [Google Scholar] [CrossRef] [Scilit]
- Liu, K.; Qu, Y.; Kim, H.-M.; Song, H. Avoiding Frequency Second Dip in Power Unreserved Control During Wind Power Rotational Speed Recovery. IEEE Trans. Power Syst. 2018, 33, 3097–3106. [Google Scholar] [CrossRef] [Scilit]
- Zhao, X.; Xue, Y.; Zhang, X.P. Fast Frequency Support from Wind Turbine Systems by Arresting Frequency Nadir Close to Settling Frequency. IEEE Open Access J. Power Energy 2020, 7, 191–202. [Google Scholar] [CrossRef] [Scilit]
- Bonfiglio, A.; Invernizzi, M.; Labella, A.; Procopio, R. Design and Implementation of a Variable Synthetic Inertia Controller for Wind Turbine Generators. IEEE Trans. Power Syst. 2019, 34, 754–764. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.K.; Yang, W.H.; Hu, Y.L.; Dzung, P.Q. Frequency Regulation at a Wind Farm Using Time-Varying Inertia and Droop Controls. IEEE Trans. Ind. Appl. 2018, 55, 213–224. [Google Scholar] [CrossRef] [Scilit]
- Morren, J.; De Haan, S.W.H.; Kling, W.L.; Ferreira, J.A. Wind Turbines Emulating Inertia and Supporting Primary Frequency Control. IEEE Trans. Power Syst. 2006, 21, 433–434. [Google Scholar] [CrossRef] [Scilit]
- Zhou, Y.; Zhu, D.; Zou, X.; He, C.; Hu, J.; Kang, Y. Adaptive Temporary Frequency Support for DFIG-Based Wind Turbines. IEEE Trans. Energy Convers. 2023, 38, 1937–1949. [Google Scholar] [CrossRef] [Scilit]
- Mauricio, J.M.; Marano, A.; Gómez-Expósito, A.; Ramos, J.L.M. Frequency Regulation Contribution Through Variable-Speed Wind Energy Conversion Systems. IEEE Trans. Power Syst. 2009, 24, 173–180. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.W.; Wang, D.L.; Liu, L.; Pan, Z.H. Frequency Control Strategy of Doubly-Fed Wind Turbine Based on Variable Parameter PI Control. New Technol. Electr. Power Energy 2018, 37, 9–17. (In Chinese) [Google Scholar]
- Yang, D.; Kim, J.; Kang, Y.C.; Muljadi, E.; Zhang, N.; Hong, J.; Song, S.-H.; Zheng, T. Temporary Frequency Support of a DFIG for High Wind Power Penetration. IEEE Trans. Power Syst. 2018, 33, 3428–3437. [Google Scholar] [CrossRef] [Scilit]
- Sun, M.; Sun, Y.; Chen, L.; Zou, Z.; Min, Y.; Liu, R.; Xu, F.; Wu, Y. Novel Temporary Frequency Support Control Strategy of Wind Turbine Generator Considering Coordination with Synchronous Generator. IEEE Trans. Sustain. Energy 2022, 13, 1011–1020. [Google Scholar] [CrossRef] [Scilit]
- Yang, D.; Jin, Z.; Zheng, T.; Jin, E. An Adaptive Droop Control Strategy with Smooth Rotor Speed Recovery Capability for Type III Wind Turbine Generators. Int. J. Electr. Power Energy Syst. 2022, 135, 107532. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Yang, D. Adaptive Speed Recovery Strategy of Doubly-Fed Induction Generator Based on Variable PI Control Coefficient. Trans. China Electrotech. Soc. 2023, 38, 4120–4129. (In Chinese) [Google Scholar] [CrossRef]
- Li, K.; An, J.; Shi, Y.; Zhou, Y.; Han, Y. Evaluation Method of Frequency Regulation Capability of Wind Power Considering Operating Point Offset. In The Proceedings of the 19th Annual Conference of China Electrotechnical Society; Yang, Q., Bie, Z., Yang, X., Eds.; Lecture Notes in Electrical Engineering; Springer: Singapore, 2025; Volume 1406, pp. 223–230. [Google Scholar] [CrossRef] [Scilit]
- Shi, Q.X.; Li, F.X.; Cui, H.T. Analytical method to aggregate multi-machine SFR model with applications in power system dynamic studies. IEEE Trans. Power Syst. 2018, 33, 6355–6367. [Google Scholar] [CrossRef] [Scilit]
- Bao, W.Y. Research on Control of Wind Power Inertia Participating in Grid Frequency Regulation. Ph.D. Thesis, Shandong University, Jinan, China, 2021. (In Chinese) [Google Scholar]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.