


Abstract
This paper proposes goal-function-based decentralized control of microgrids. In addition to being an instrument for maintaining the grid voltage and frequency stability, each grid-tie inverter generates a current component with the aim of compensating for voltage distortion in the node where it is connected. The designed goal-function does not need to rely on the assumption that a microgrid is dominantly inductive or resistive to derive its control law, as is mostly the case with the droop-based approach. The priorities of the proposed scheme can be adjusted according to user preferences. In addition, the control algorithm is independent of network topology, can be applied in both islanded and non-islanded microgrids, and secure system scalability. The proposed method is verified by detailed simulations.
1. Introduction
A microgrid (MG) can be defined as an entity in which generation sources are connected to the AC power system through power electronic interface converters to meet both grid-connected and islanding operations [1,2]. Among others, the following problems inevitably arise during MG operation: (1) The lack of natural system inertia caused by the high penetration of renewables can result in significant frequency variation in islanded MGs; (2) The power exchange between the MG nodes is strongly coupled with frequency and voltage variation and thus affects MG stability; (3) Distribution grids and MGs are characterized by small X/R ratios, limiting the applicability of traditional control methods. Furthermore, the loads connected in a microgrid can be both linear and nonlinear. Nonlinear loads deteriorate the power quality by drawing harmonic currents. Drawing nonlinear currents will make the voltage waveform non-sinusoidal, which may prove harmful for other loads connected to the system [3]. To improve power quality and mitigate higher voltage and current harmonics in microgrids [4], several methods inspired by solutions applied in a low voltage distribution network, such as passive and active filters, D-STATCOM, and D-FACTS [5], have been proposed. In [6], D-STATCOM using a reinforcement learning algorithm for enhancing power quality in MG was presented. Methods for active power filtering and reactive power compensation with optimized control parameters have been offered in [7,8]. Ref. [9] proposes a control architecture of distributed generator inverters and shunt active power filters in microgrids to compensate voltage harmonics in a coordinated way. In [10], a wideband series harmonic voltage compensator as an extension to series active power filter has been proposed. Its function aims to form virtually zero high-frequency impedance at the output of the paralleled grid-tied inverter to assure system stability under any operating conditions.
The state-of-the-art tendency is to employ multifunctional capabilities of grid-tied converters, such as inverters, interfacing distribution generation to deal with power quality issues. The main role of the distribution generation (DG) inverter is to adjust the output voltage phase angle and amplitude in order to control the active and reactive power flow. However, compensation of power quality problems, such as voltage harmonics and unbalance, can also be achieved through proper control strategies [11]. In this way, grid-tied converters become multifunctional [12,13].
In the literature, the MG control algorithm has been generally divided into different hierarchical levels, usually referred to as primary, secondary and tertiary control levels. Since the primary control level has the fastest response and can be operated without any communication links, it is widely preferred for implementing harmonic mitigation methods. In [14], harmonic mitigation methods have been classified into 5 groups: Modified Droop Controller, Harmonic Droop Controller, Virtual Impedance, PR Controller, Repetitive Controller and Other Methods.
Harmonic Droop Controller [15,16] and Modified Droop Controller in combination with Harmonic Droop Controller [17,18] are used to modify the voltage reference generated by a standard droop control (P-f and Q-V) to compensate for voltage harmonics at the point of common coupling with loads. The virtual impedance method [19,20,21] is based on the modification of the grid-tie inverter current, which is then added to the inverter voltage. The aim is to reshape the output impedance in the direction of harmonic suppression. Adaptive virtual impedance methods [22,23] have been developed to improve the control robustness regarding system parameters. Feeder impedance estimation based on the microgrid central controller and inherent harmonic signals introduced by a nonlinear or unbalanced load was proposed in [24]. In [25], a combination of virtual impedance with droop control was proposed, where droop distributed virtual impedance among distributed generation units. In order to reconcile the issue between harmonic residual capacity (inverter capacity to share harmonic power) and virtual impedance, a nonlinear droop scheme was proposed in [26]. Regarding so-called Virtual Synchronous generator (VSG)-based microgrids, several methods for voltage harmonics mitigation have been developed. The method of reducing the impedance of VSG in order to prevent a significant voltage distortion induced by a non-linear load in the islanded microgrid was proposed in [27]. Another method for VSG-based microgrids, which can separately mitigate the grid harmonic current caused by nonlinear loads and grid background harmonics, was proposed in [28]. A decentralized inverter control scheme with an advanced voltage injection technique that minimizes the voltage unbalance factor and reduces voltage total harmonic distortion in a low-voltage AC microgrid using Pareto multi-objective optimization was proposed in [29]. A distributed and selective harmonic current compensation without interfering with the converter’s power exchange based on master/slave architecture was proposed in [30]. There has also been growing literature about the application of machine learning in solving power quality challenges in a distribution grid and microgrids [31,32].
The method proposed in this paper is based on a goal function with the aim of addressing several microgrid control objectives. It extends the self-stabilizing primary control of microgrids proposed in [33], which itself cannot cope efficiently with the higher harmonics by means of the ability to compensate the voltage distortion. The proposed method maintains the advantages from [33], such as: (1) Voltage and frequency deviations are strictly kept within predefined but adjustable limits. This is in accordance with the grid operator demands and future MG code requirements and hence contributes to the MG reliability and stability; (2) The goal function approach provides active power production consistent with predetermined power-exchange requirements, without compromising the MG stability; (3) Plug-and-play capability is ensured, and the control framework is MG topology-agnostic (only nodal parameters are required), supporting the system’s scalability. Additionally, the proposed controller is apt for both grid-connected and islanded MG operational modes; (4) The proposed control algorithm can be easily integrated with hierarchically higher control levels (e.g., secondary and tertiary control). These advantages combined with the ability to limit total harmonic distortion (THD) are inherent for the method proposed in this paper. In addition, the priorities of the proposed scheme (voltage deviation, frequency deviation, harmonics distortion) can be adjusted according to user preference, which contributes to the high level of flexibility.
In the continuation, this paper is organized as follows: In Section 2, the main idea behind the so-called “Decentralized self-stabilizing primary control of microgrids” [33] is briefly explained for the purpose of readability, since it is a base upon which the proposed harmonic compensation method proposed in this paper is built. The derivation of the proposed method and the implementation of the overall control system are presented in Section 3. The verification through simulation results is given in Section 4, followed by the conclusions in Section 5.
2. Decentralized Self-Stabilizing Primary Control of Microgrids
The strategy proposed in this paper extends the concept of the decentralized self-stabilizing primary control of microgrids proposed in [33] with harmonic mitigation capability. For the sake of readability, the main points of this concept are briefly explained here.
Frequency and voltage stability are the two most important goals for a microgrid’s smooth operation. This becomes even more apparent when peer-to-peer energy exchange among microgrid prosumers is required. Consequently, volatile power flows pose an additional challenge for microgrid stability.
Obviously, there are several conflicting goals at hand: voltage and frequency stability and free power exchange. One solution to coping with such a challenge might be to quantify all the goals of interest by one goal function.
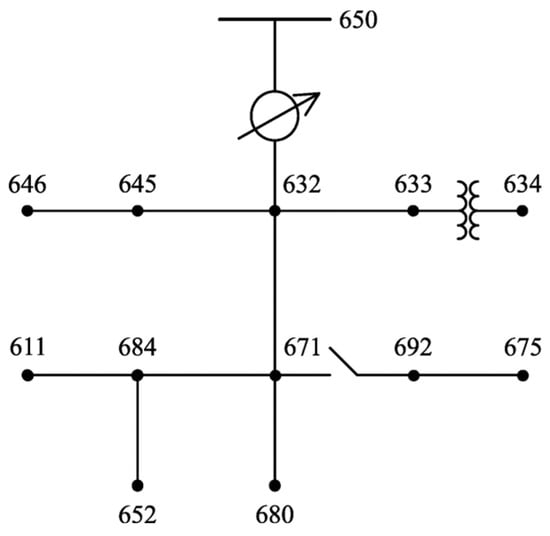
For each microgrid node (Figure 1), a local goal function was proposed
where is the net active power output of the node , is the node’s net active power reference, is the node’s voltage, is the node’s reference voltage, and are weight functions that determine a weight of relative deviation of the active power and voltage:
where and are control parameters, while is the maximal permittable voltage deviation. Note that the output of function grows rapidly when the voltage deviation approaches its limit, in contrast to function . Obviously, voltage stability is a much more important goal than achieving a desired power exchange. In this way, the control strategy defined by (1) has embedded voltage stabilization. It is assumed that grid nodes have different power references in accordance with the requirement for free energy exchange, while the voltage reference is the same for all nodes. The mechanism for frequency self-stabilization, which is of the utmost importance, will be explained in the continuation.
Figure 1.
Example of an IEEE typical microgrid topology.
The voltage RMS and phase angle should be controlled at each grid node so that the node open-loop dynamics is given as
where and are the control variables. Note that when only the fundamental voltage harmonic is considered, as is the case at this moment, voltage magnitude and its RMS are mutually replaceable (by the multiplication coefficient ), so instead of voltage magnitude, RMS can be introduced in (4).
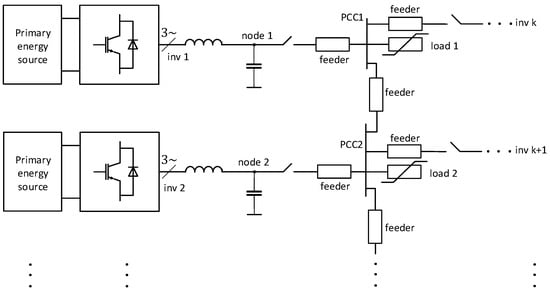
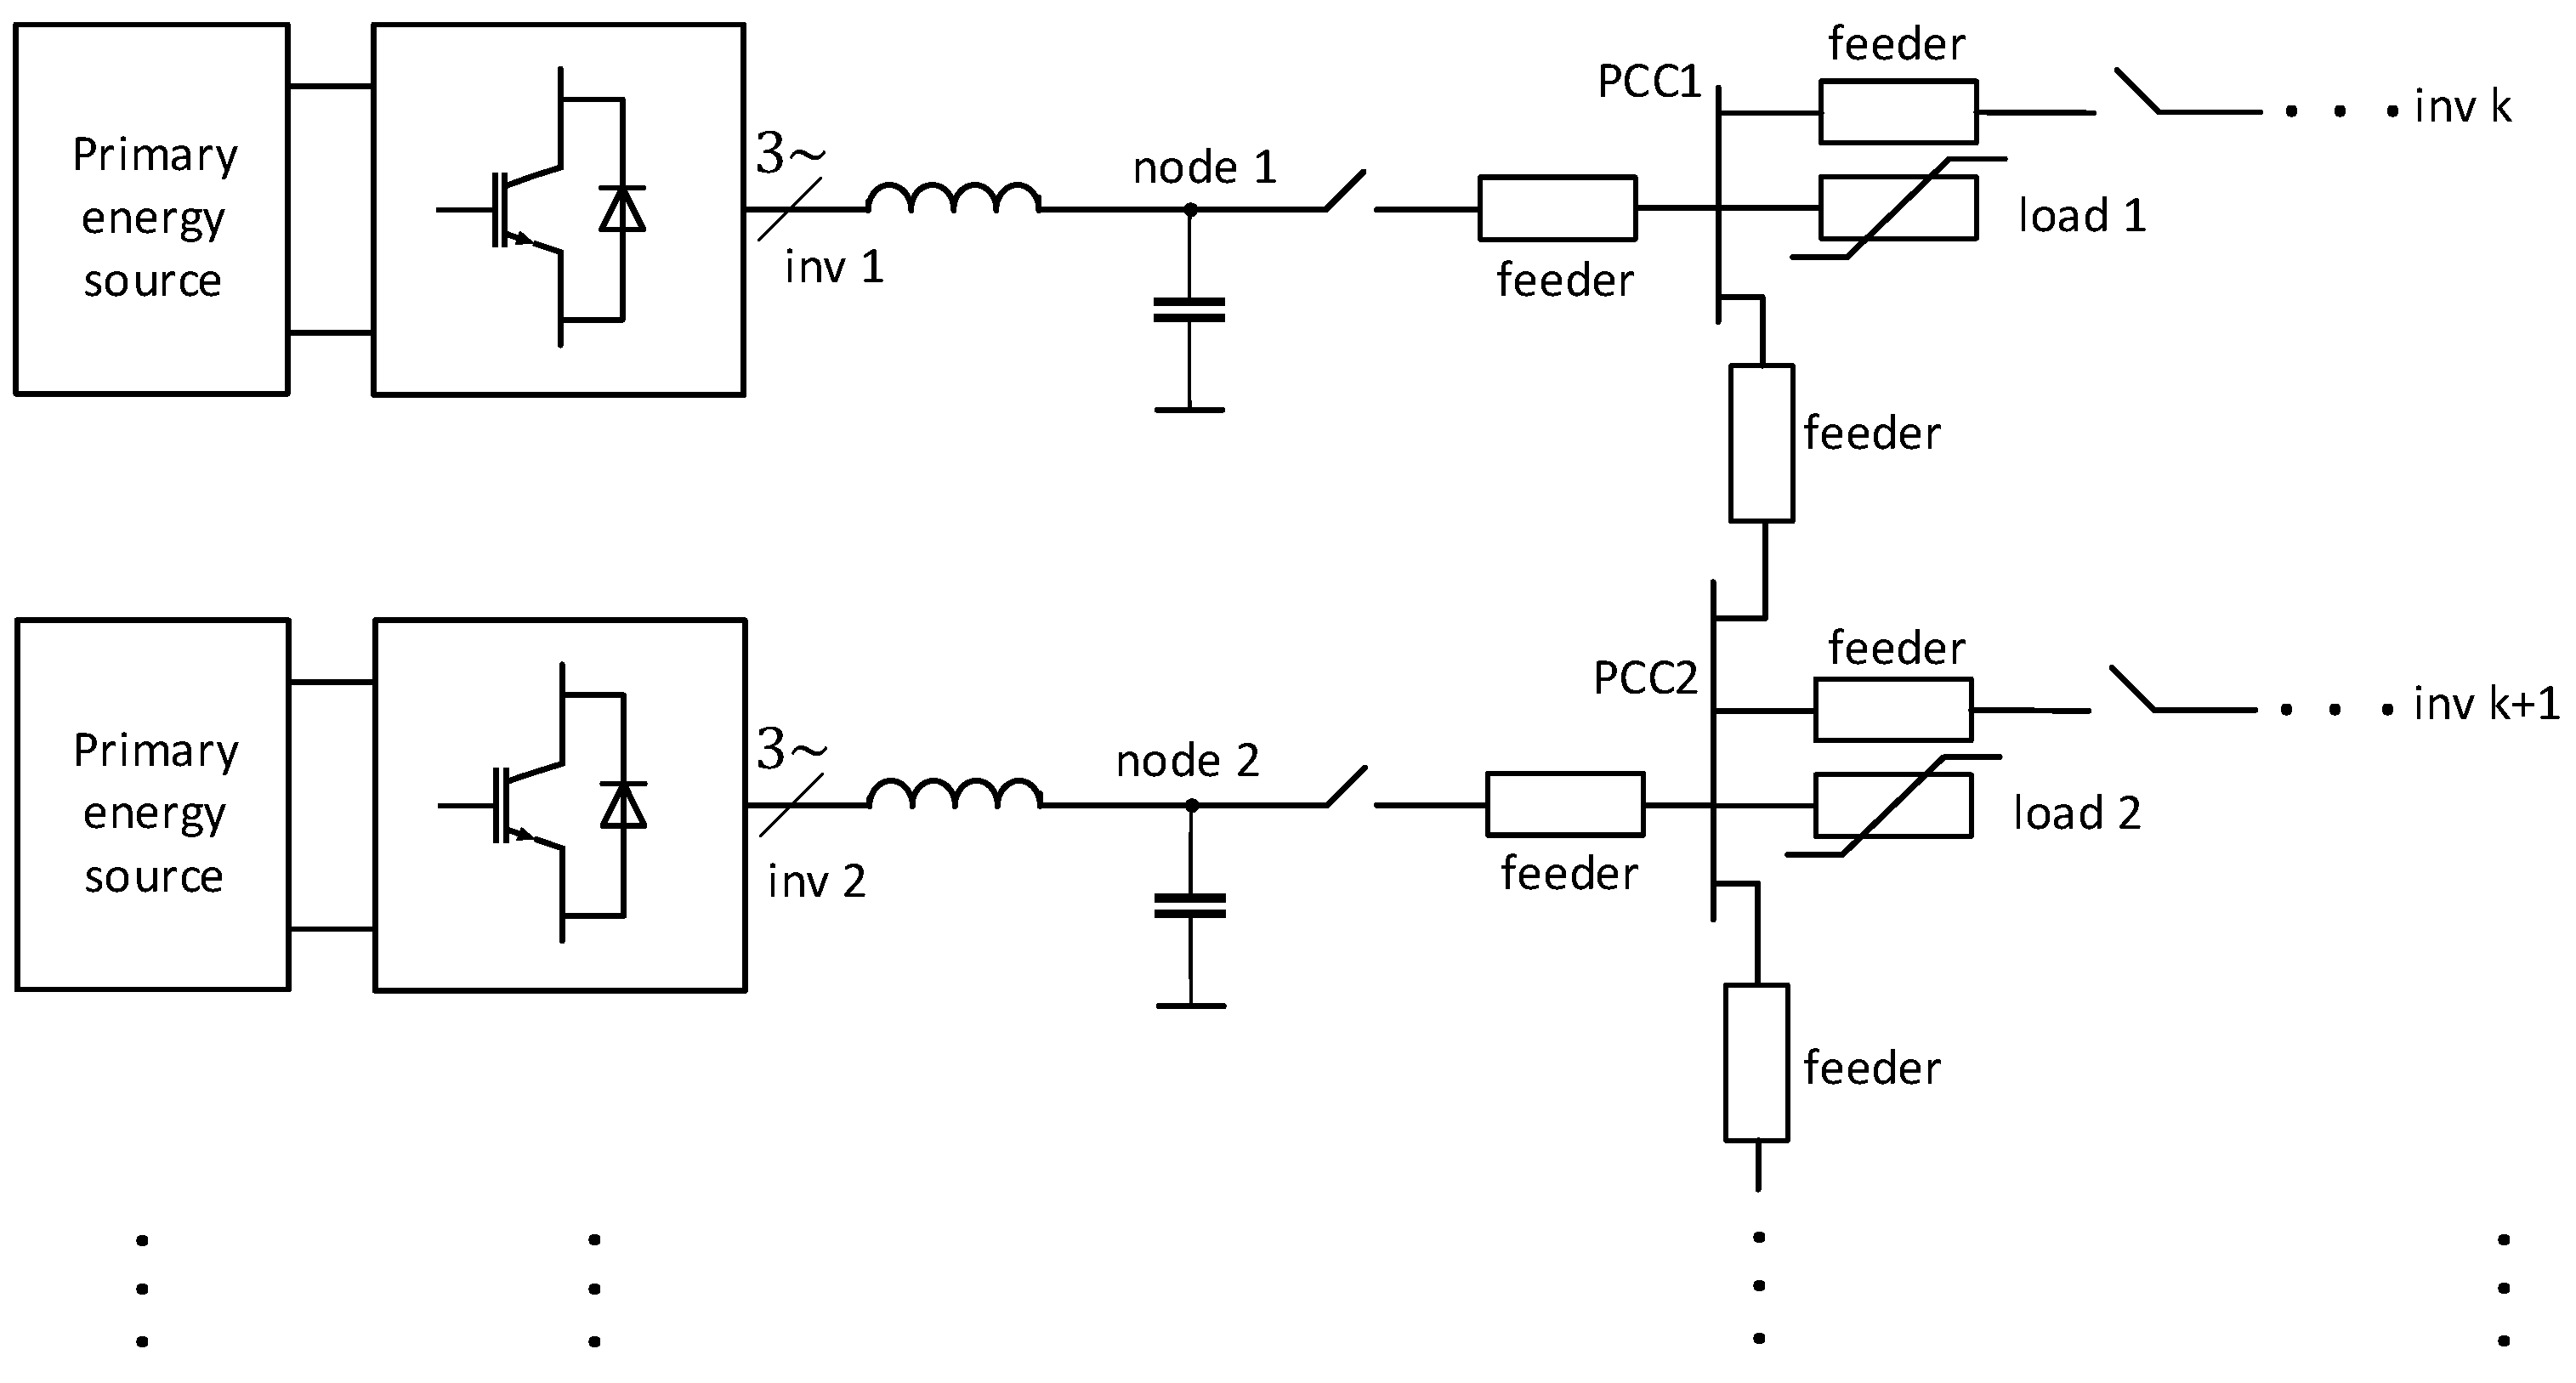
It is assumed that every microgrid node can be controlled by an inverter in the role of interface between a primary energy source (solar, wind, energy storage) and the microgrid. Therefore, a microgrid at hand could be depicted in a more detailed level, as displayed by Figure 2.
Figure 2.
Inverters in the role of controlling microgrid voltage phasors.
Note that the term “node” is employed for the output of any inverter, i.e., an output of its LC filter, because this point is directly controlled throughout an inverter operation, while the point where loads and inverter systems are connected is designated as a Point of Common Coupling (PCC).
Following Equations (1) and (4), the control law for node was defined as
where local node parameters and are positive real coefficients which can affect the dynamics of the voltage and frequency change.
Note the represents the frequency deviation from the nominal (reference) frequency .
The function belongs to a barrier-type functions which imposes a limit on a control variable because it is of the outmost importance to keep frequency stability.
The output, per-phase active and reactive power of the node can be calculated as in [34]:
where and are a conductance and susceptance between any two neighboring nodes and respectively, and are voltage RMS values while and are phase angles of nodes and .
Taking this into account and following Equations (1), (5) and (6), the control law can be rewritten as
where and . Expressions (8) and (9) essentially define the value of voltage phasor in each microgrid node to be achieved in order to fulfill the required goals.
The stability proof of the control law defined by Expressions (8) and (9) can be found in [33,35].
3. The Proposed Goal-Function-Based Harmonics Mitigation
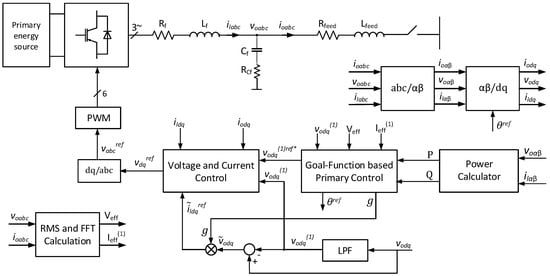
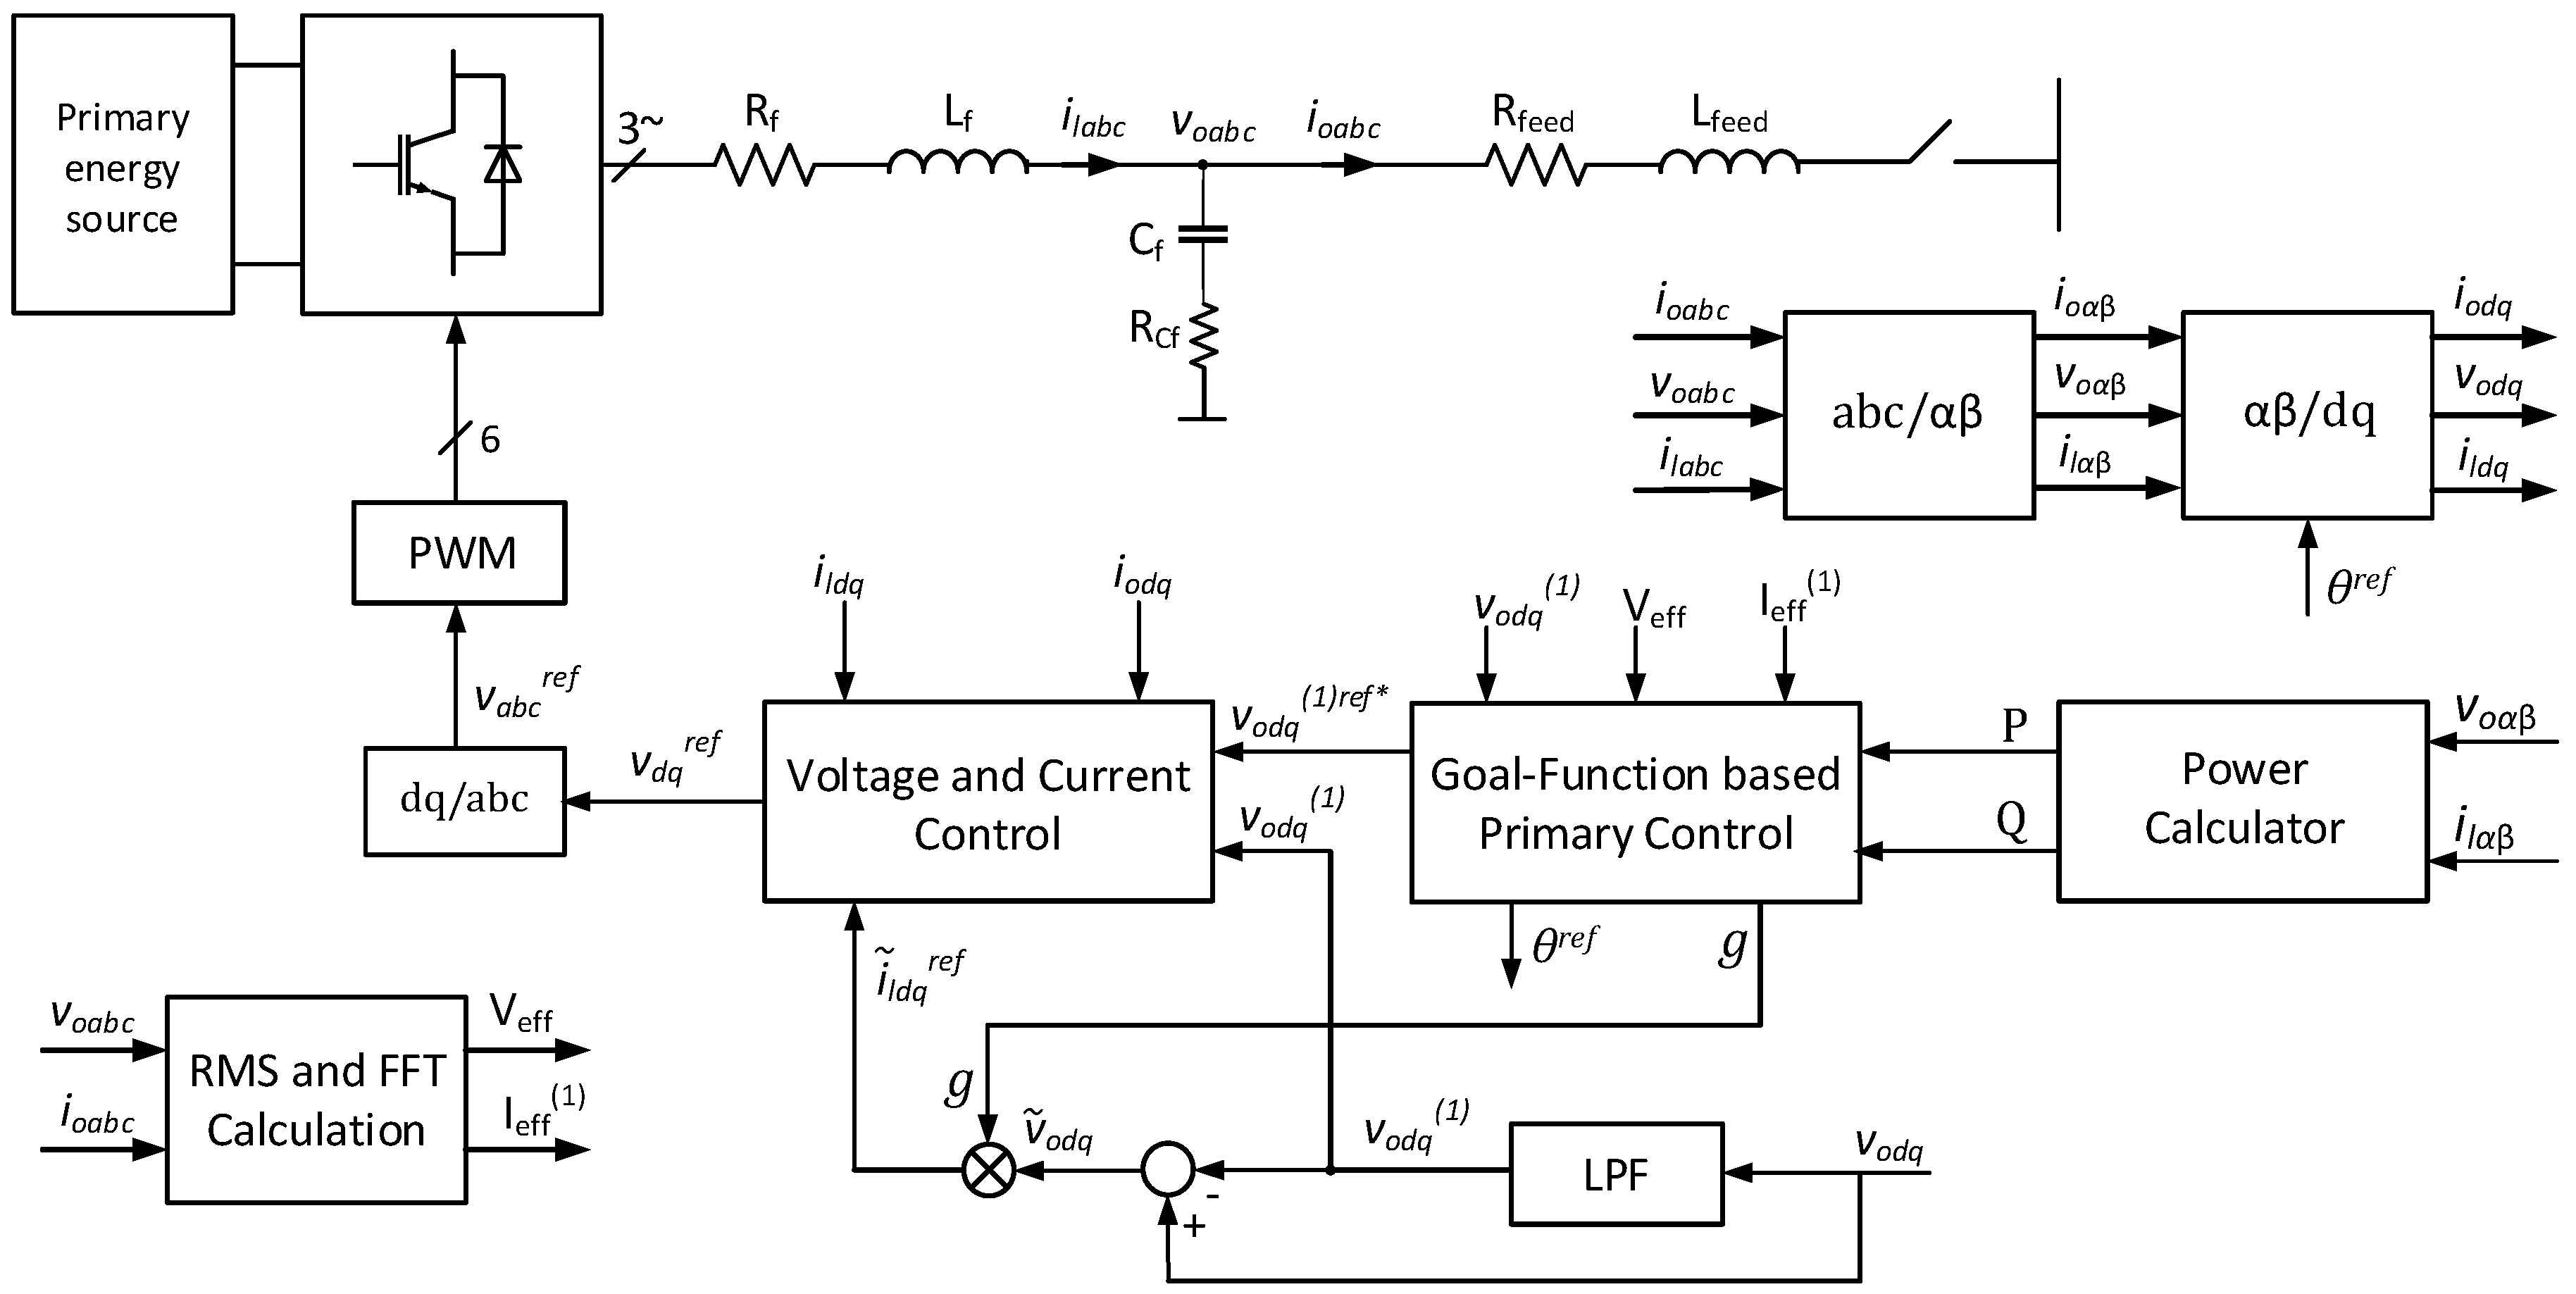
The proposed control concept is decentralized; therefore, the system control description (Figure 3) will be explained on a single inverter system taken from the microgrid depicted in Figure 2.
Figure 3.
The system control scheme.
The core of the overall control structure is the Goal-Function-Based Primary Control, which gives the key control variables: the fundamental harmonic of the node reference volage phasor and a gain used to compensate for higher harmonic components of that voltage.
The control law defined in Section 2 deals only with power at the fundamental frequency (fundamental harmonic). Therefore, to improve voltage quality in the case of higher harmonics (e.g., produced by non-linear loads), the control law must be extended by an additional goal that will suppress higher voltage harmonics in microgrid nodes and points of common coupling. Therefore, in Section 3.1, the power of higher harmonics will be calculated, followed by a derivation of the proposed controlled law in Section 3.2. Finally, its step-by-step implementation based on Figure 3 will be presented in Section 3.4 and Section 3.5.
3.1. The Power of Higher Harmonics
The apparent power can be expressed as
where and are active and reactive power at the fundamental harmonic, while presents the “harmonics power”, essentially an undesired component that should be mitigated.
In a three-phase balanced AC system, the power values per phase are
where and are RMS values of the voltage and current respectively, and are RMS values of the first voltage and current harmonic, while is the phase shift between the fundamental harmonic of voltage and current.
The harmonics power can then be calculated as
Volage and current RMS value, and , can be decomposed [36] on RMS value of the fundamental harmonic and RMS value of the rest of higher harmonics
where and are the voltage and current RMS values of the h—th harmonic, respectively.
The value of H can be calculated by combining (12) with (13) and (14)
The last term of the equation, is significantly smaller than the remaining ones and can be neglected for all practical purposes, so
3.2. The Control Law Formulation
The control variable will be defined such that
Employing (17), (16) can be formulated as
Now, an additional term, will be included in the goal function (1). This term will make the controlling agent aware of the harmonic disturbance and will make the states in which the harmonic disturbance is lower preferable.
where
and is a real coefficient, i.e., is a linear function with the argument . Note that other functions could have been chosen for . It is only important that they grow slower than and defined by (2) and (3), so that the relative importance of harmonic mitigation is lower than that of keeping the network stable and achieving desired power exchange. Note that the node’s index l was omitted from (19) for the sake of simplicity. Keeping all this in mind, the new goal function can be presented as
where is “the old” goal function defined by (1).
Applying (5), the control variables and are now calculated as follows:
Note that the term is already defined by (8).
The second term from (22) becomes .
To calculate the term , the harmonics power from (16) must be reformulated by means of variable
and therefore
Finally,
where can be calculated as in (8).
The value of control variable can be obtained as
where has been already given by (9) and is defined by (20).
Since (23) does not depend on θ, .
Therefore,
Finally, in analogy with and , a new variable is defined as
At the other side, the variable is calculated from the goal function as
Variables and define the voltage phasor reference value, while directs the higher harmonics compensation, as will be described in detail in Section 3.5. To summarize, Equations (4), (25), (27)–(29) are implemented as a key part of the Goal-Function-Based Primary Control (GFBPC) for achieving a decentralized primary microgrid control with higher harmonics suppression. The implemented equations are listed in Table 1.
Table 1.
GFBPC equations.
In the Appendix A it is shown that the proposed decentralized control strategy guarantees the boundedness of both voltage and frequency deviation, as well as the boundedness of harmonic distortions.
3.3. Goal-Function-Based Primary Control Implementation
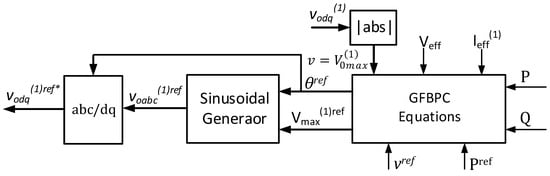
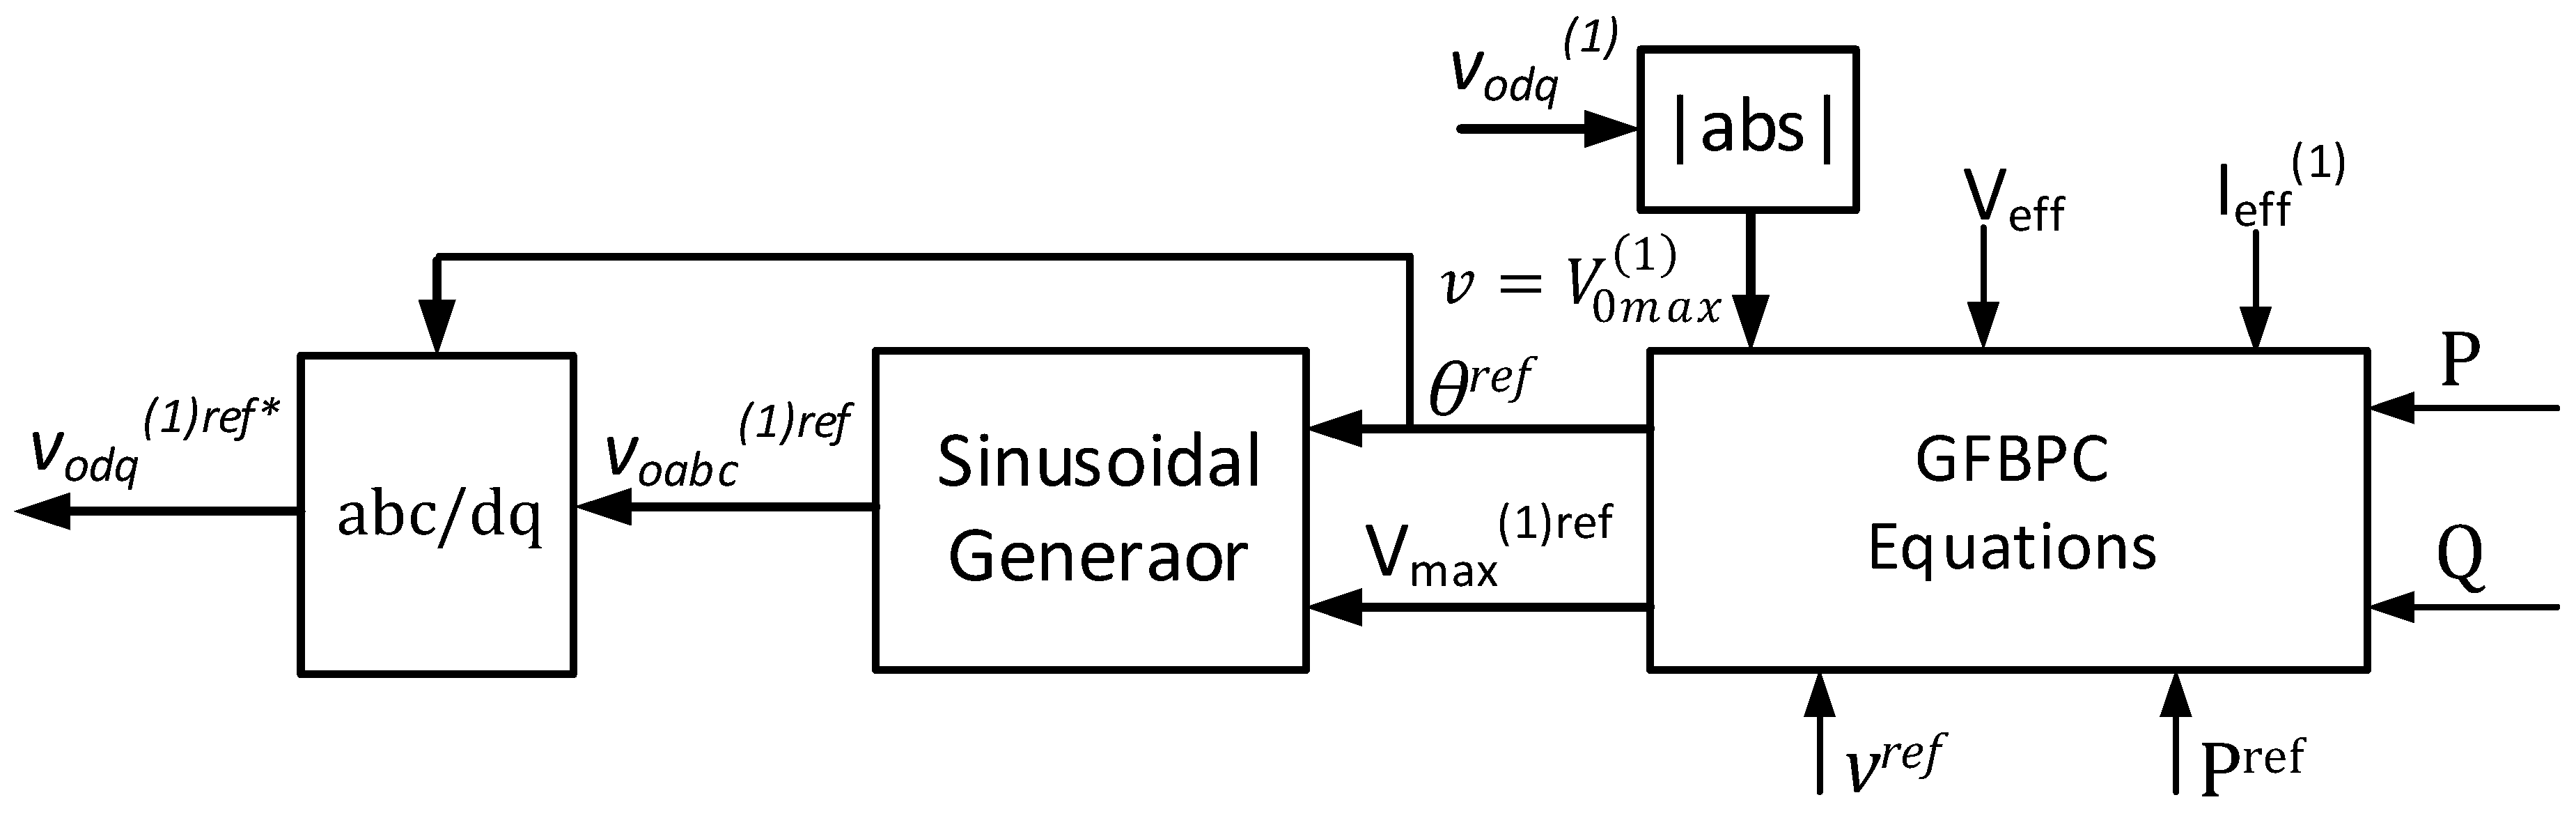
Figure 4 shows the Goal-Function-Based Primary Control elements.
Figure 4.
Elements of the Goal-Function-Based Primary Control.
The variable is obtained via the magnitude of the node’s voltage fundamental harmonic in the following way:
while and are filtered values of the voltage components and procured from the three phase voltages by means of dq transform, where the transformation angle is one of the Goal-Function outputs. After applying the magnitude invariant abc/dq transformation on the signal with the fundamental and higher harmonics, the fundamental harmonic will be transformed into a DC value, while higher harmonics will still be at higher frequencies. Therefore, the fundamental harmonic can be extracted by employing a low-pass filter, such as
where is chosen as a compromise between the satisfactory harmonics’ attenuation and filter dynamics.
Inputs in the Equations Calculator, P and Q are obtained from the Power Calculator block, while and are calculated (Figure 3) as a RMS of the voltage and applying FFT to the current respectively. The input is set to the value of zero. In the case when the secondary control would be included, this variable would be fed from the secondary control subsystem.
The Equations Calculator outputs and are employed to set the reference value of the voltage fundamental harmonic which is fed to the Voltage and Current Control block. The angle is used as an input for all abc/dq and dq/abc transformations.
3.4. Goal-Function-Based Primary Control Implementation
Inverter apparent power can be calculated using magnitude invariant reference frame as
and consequently
Variables and could contain power components at higher harmonics and , beside the desired active and reactive power and , i.e.,
Therefore, active and reactive power and are obtained by filtering and applying (31).
3.5. Voltage and Current Control
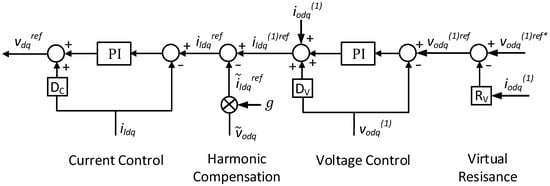
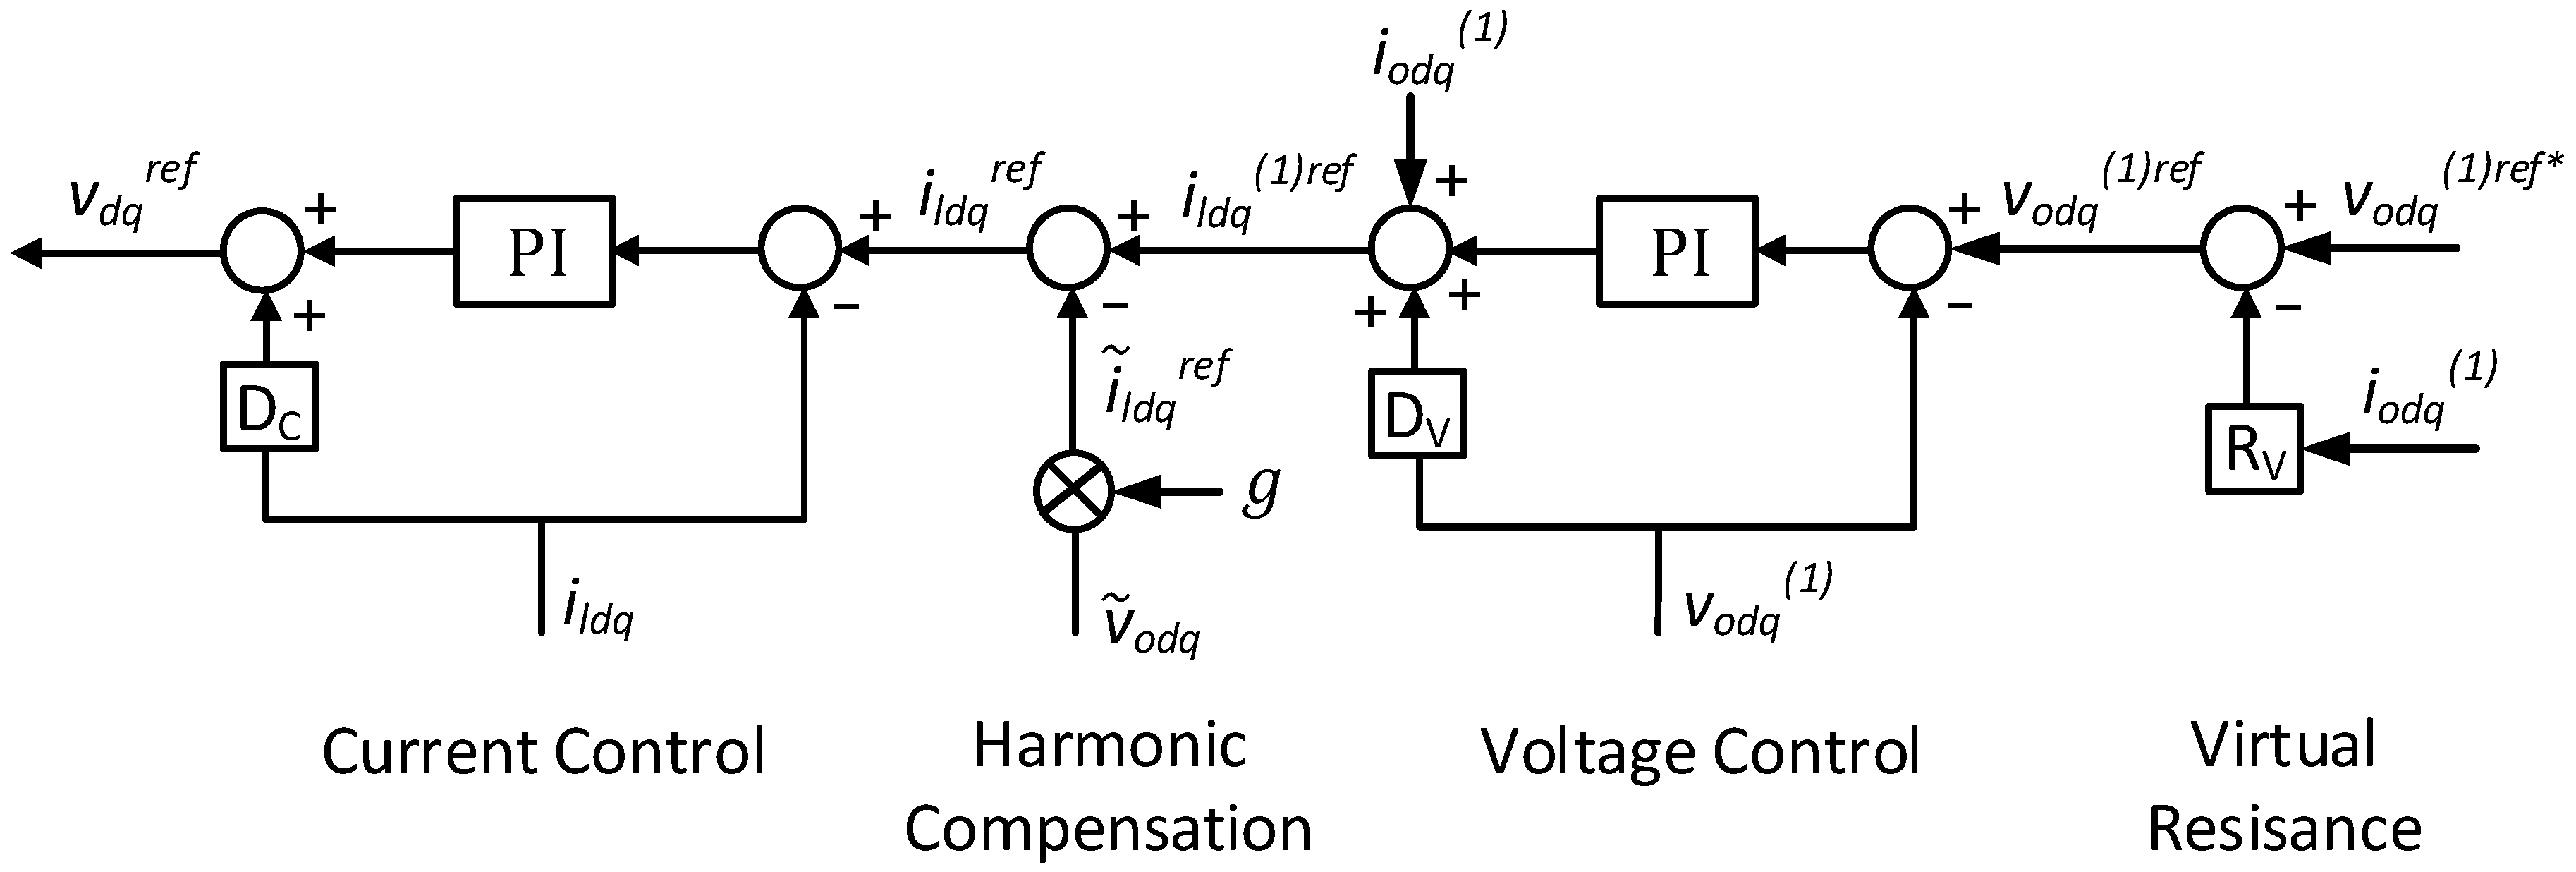
The inverter local voltage and current structure shown in Figure 5 is implemented in the rotating (dq) system. It consists of four main elements: Virtual Resistance, Voltage Control, Harmonic Compensation and Current Control.
Figure 5.
Voltage and current control structure.
The virtual resistance increases the system oscillation damping [37], which is a particularly convenient feature in a microgrid. When droop control is applied, a very often approach is to design a virtual inductance beside a virtual resistance. The role of virtual inductance (reactance) is to improve active and reactive power decoupling [38]. Namely, the droop-oriented primary control is based on a linear (droop) approximation of expressions for active and reactive power flow between any two nodes, as presented in (7). When the grid is purely resistive or inductive, such an approximation works rather satisfactorily. However, when the values of line reactance and resistance are comparable, an additional solution must be adopted. One such solution is the inclusion of a virtual reactance. In this paper, there is no need to employ a virtual reactance because the proposed method is not based on linear approximations, and it is one of its important advantages.
The voltage fundamental harmonic reference which is to be fed to the voltage controller is calculated from the voltage as an output of the Goal-Function by subtracting the voltage drop on the virtual resistance:
The Voltage Controller contains a PI regulator accompanied by a decoupling element , where is a capacitor of the LC filter (see Figure 3). Namely, neglecting the voltage drop on as an equivalent series resistance of ,
After applying dq transform to arbitrary variable , , Equation (36) becomes
i.e., control of the fundamental voltage harmonic is obtained as
where d and q current components are filtered out from by applying (31).
The output of the voltage controller is the reference to the inverter’s fundamental current harmonic . However, the currents (i.e., ) due to non-linear loads might contain components at higher “lower harmonics”, such as fifth and seventh. High-order harmonics as a consequence of PWM switching are not considered by means of control structure since the LC filter is designed to deal with them. In order to address the lower harmonics, the Harmonics Compensation block (Figure 5) is added. It measures the harmonics component of the volage , . The voltage is obtained by subtracting the fundamental harmonic component from the overall voltage (Figure 3). Multiplying by the control variable from (28) and (29), aimed to suppress the total harmonic power; the harmonic current is generated. Addition of to the with the negative sign is set to compensate for the distorted currents responsible for the voltage harmonic distortion.
Finally, the current controller consists of a PI regulator with a decoupling element , in a similar way as it was the case with the Voltage Controller.
4. Simulation Results
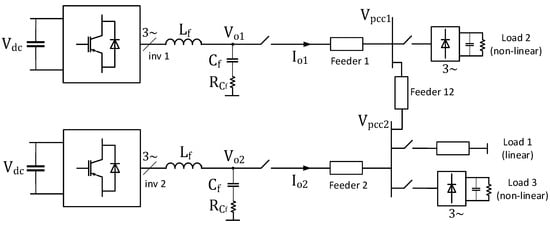
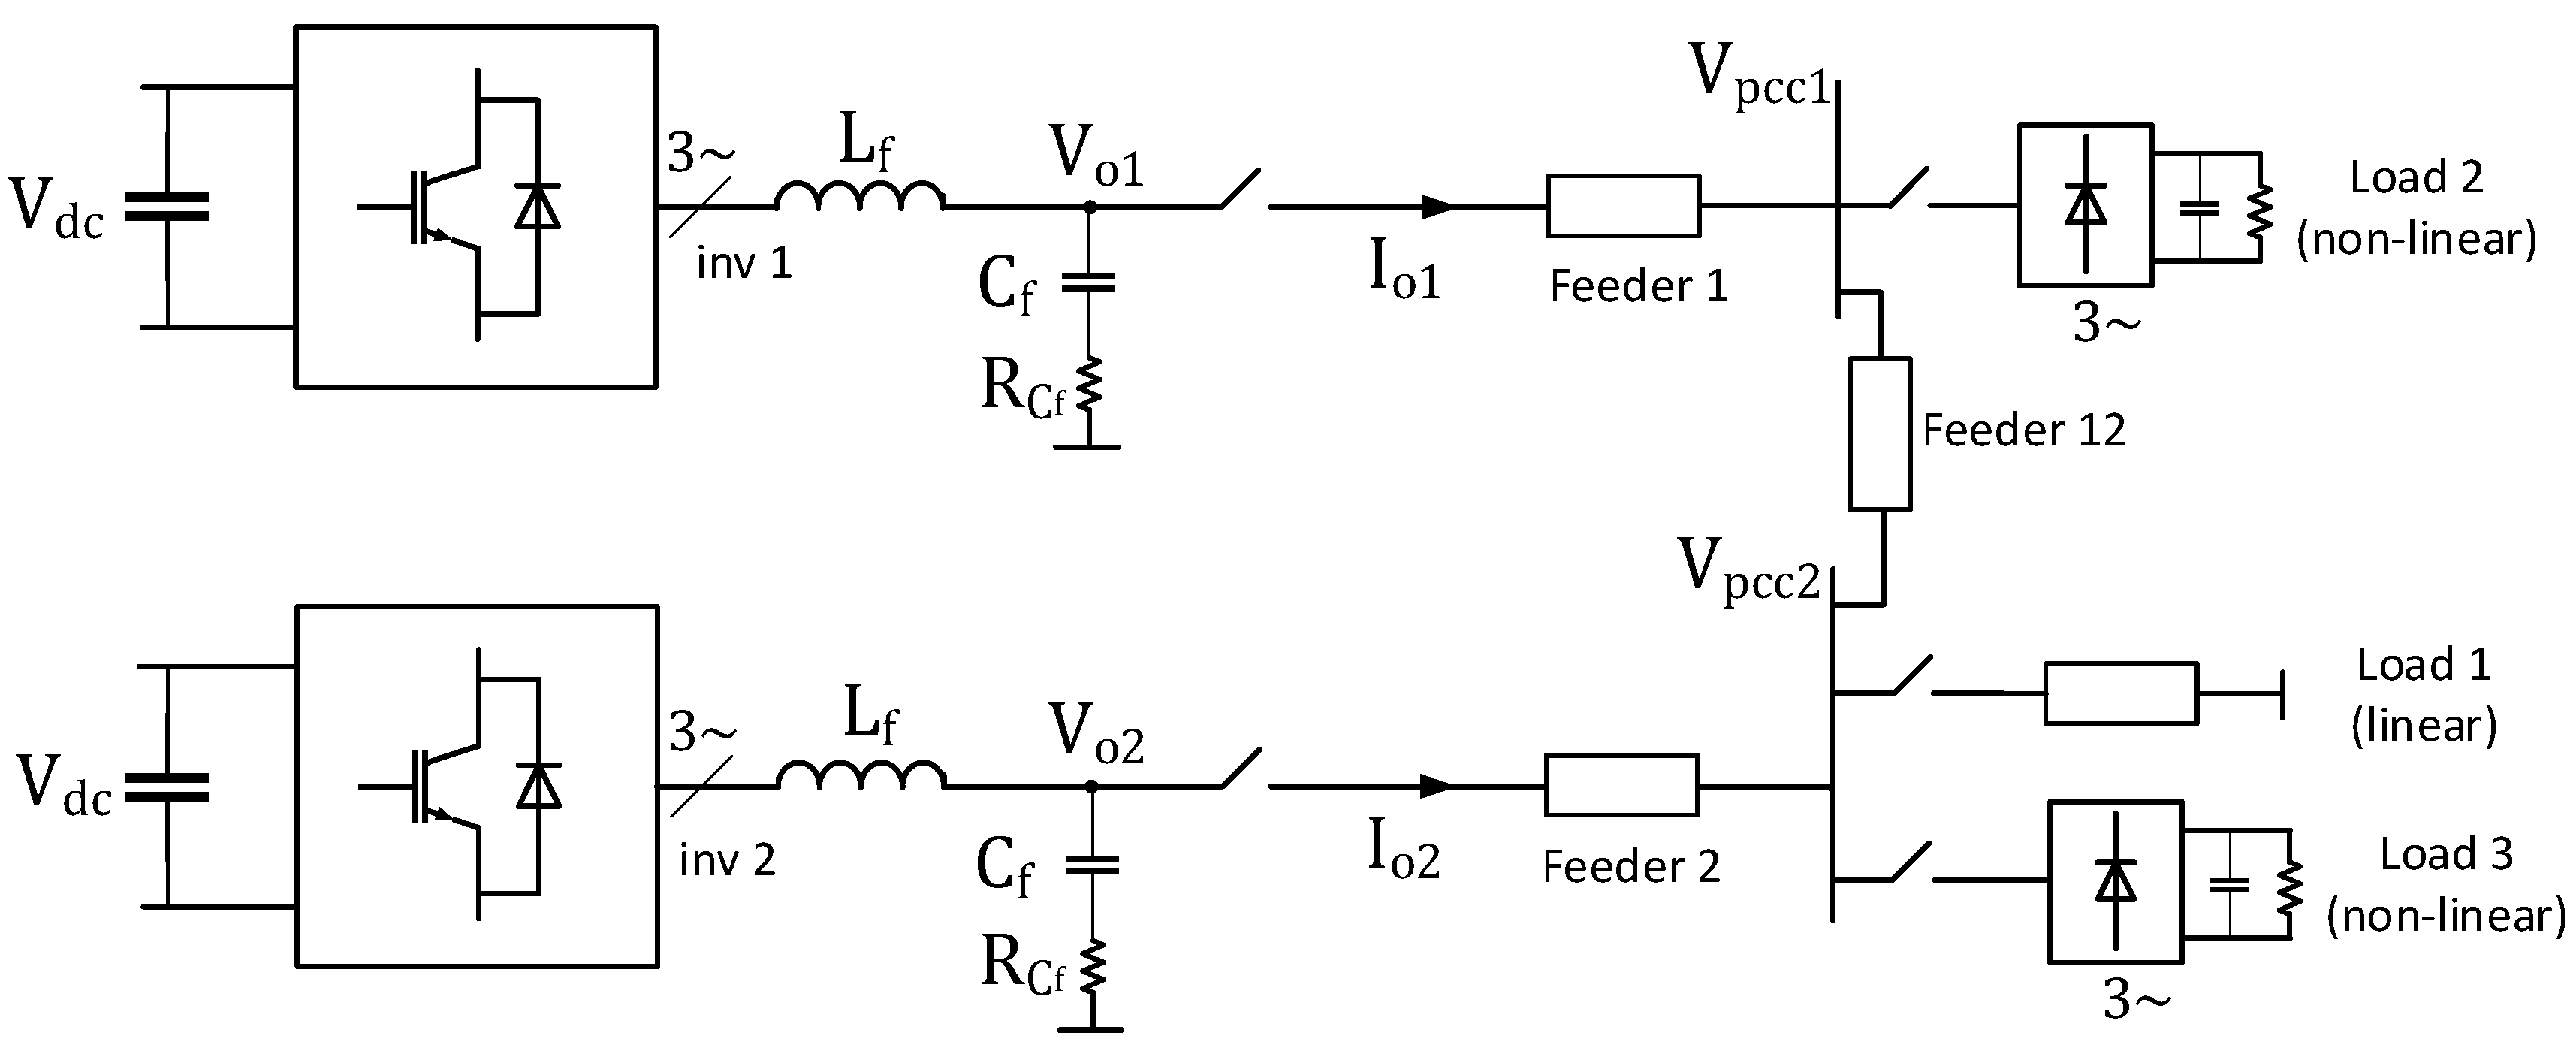
The proposed harmonics mitigation control strategy is tested in Matlab/Simulink (https://www.mathworks.com/products/matlab.html, 18 September 2024) on the system with two inverter units (Figure 6) with two points of common coupling, PCC1 and PCC2, where both non-linear and linear loads in different moments are connected. It is assumed that both inverters have identical parameters, which are given in Table 2.
Figure 6.
Simulated system.
Table 2.
Inverter nominal system parameters.
LC output filter is designed following the guidelines [39] according to which the filter inductance should be chosen based on the maximal permissible inverter current ripple (generally 15–25%, in this paper 18% is chosen), while as a rule of thumb
While is a nominal grid frequency, Hz, is a switching frequency from Table 2, and is an LC filter resonance frequency
For LC filter damping, passive damping is chosen, with damping resistor given as
where ξ is a damping factor, chosen as ξ = 0.6.
Parameters of the LC filter are given in Table 3 together with feeders’ and linear load (Load1) parameters.
Table 3.
LC filter, load and feeder’s parameters.
Note that the feeder impedances have comparable inductive and resistive components, where the Feeder 12 is predominantly resistive, while other two are predominantly inductive. Feeder 1 has exactly three times greater impedance than Feeder 2, i.e., the distance between Inverter 1 and its point of common coupling (PCC1) is three times longer than the distance between Inverter 2 and PCC2.
Non-linear loads (Load 1 and Load 2) are three-phase diode rectifiers, chosen here because they are very common consumer components and because they are among the highest harmonic polluters. The value of the DC bus capacitors of each rectifier is set to 1 mF, while they are loaded with a resistive load of 100 Ω.
Control system parameters, such as Goal-Function-Based Harmonic Mitigation (GFBHM) parameters, are given in Table 4, while voltage and current PI controller parameters are given in Table 5.
Table 4.
GFBHM parameters.
Table 5.
Voltage and current controller parameters.
All parameter values have been determined empirically. Parameters and have rather small values since they are multiplied with the square value of power, as defined in (2) and (20), respectively. In addition, note that the value of is an order of magnitude lower than since, the goal of preserving voltage stability is of much higher importance than harmonics suppression. Furthermore, GFBHM parameters , and are all set to the value 1. Parameters B and G, although expressed in [S], S = 1/Ω, are the controller parameters.
The simulation sequence is designed as follows:
- GFBHM control is off at the start;
- Load 1 (a linear load) is connected from the start;
- At the moment t = 0.3 s, Load 2 (a non-linear load) is connected. GFBHM control is still off;
- At the moment t = 0.75 s, GFBHM control is on;
- At the moment t = 1.2 s, Load 3 (a non-linear load) is connected;
- At the moment t = 1.7 s, Load 2 and Load 3 are disconnected, Load 2 is still connected, and GFBHM control is still on;
- The simulation ends at the moment t = 2 s.
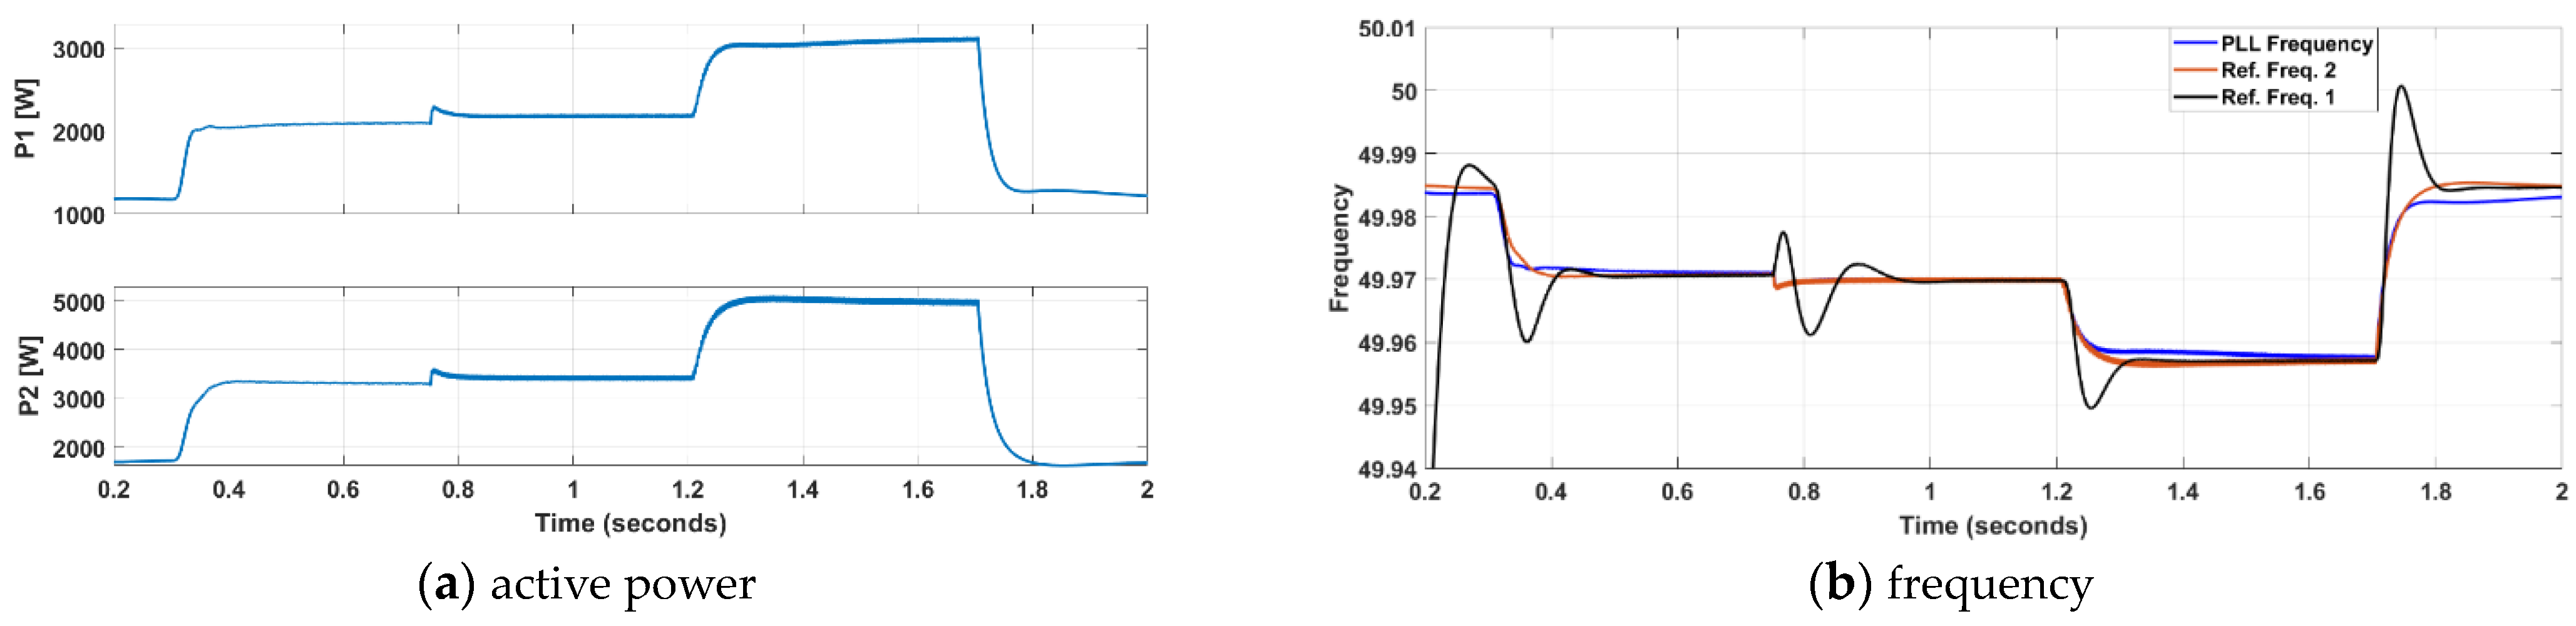
Figure 7 presents the active power generated from both inverter units (P1 and P2) and system frequency. Inverters (inv. 1 and inv. 2 from Figure 6) share the load according to their GFBHM parameters, which are set equally. Since the impedance of Feeder 1 is three times bigger than the impedance of Feeder 2 and more than six times bigger than the impedance of the interconnecting Feeder 12, inverter 2 takes a higher share. In Figure 7b, reference frequencies generated by GFBHM control of each inverter system (Ref. Freq 1 and Ref. Freq. 2) are displayed together with the frequency measured by the PLL (PLL Frequency). It can be noticed that due to the goal function’s highest priority of keeping the frequency stable, frequency is kept very tightly to the reference value of 50 Hz, safely into the borders of 50 Hz +/−1%.
Figure 7.
Active power and frequency.
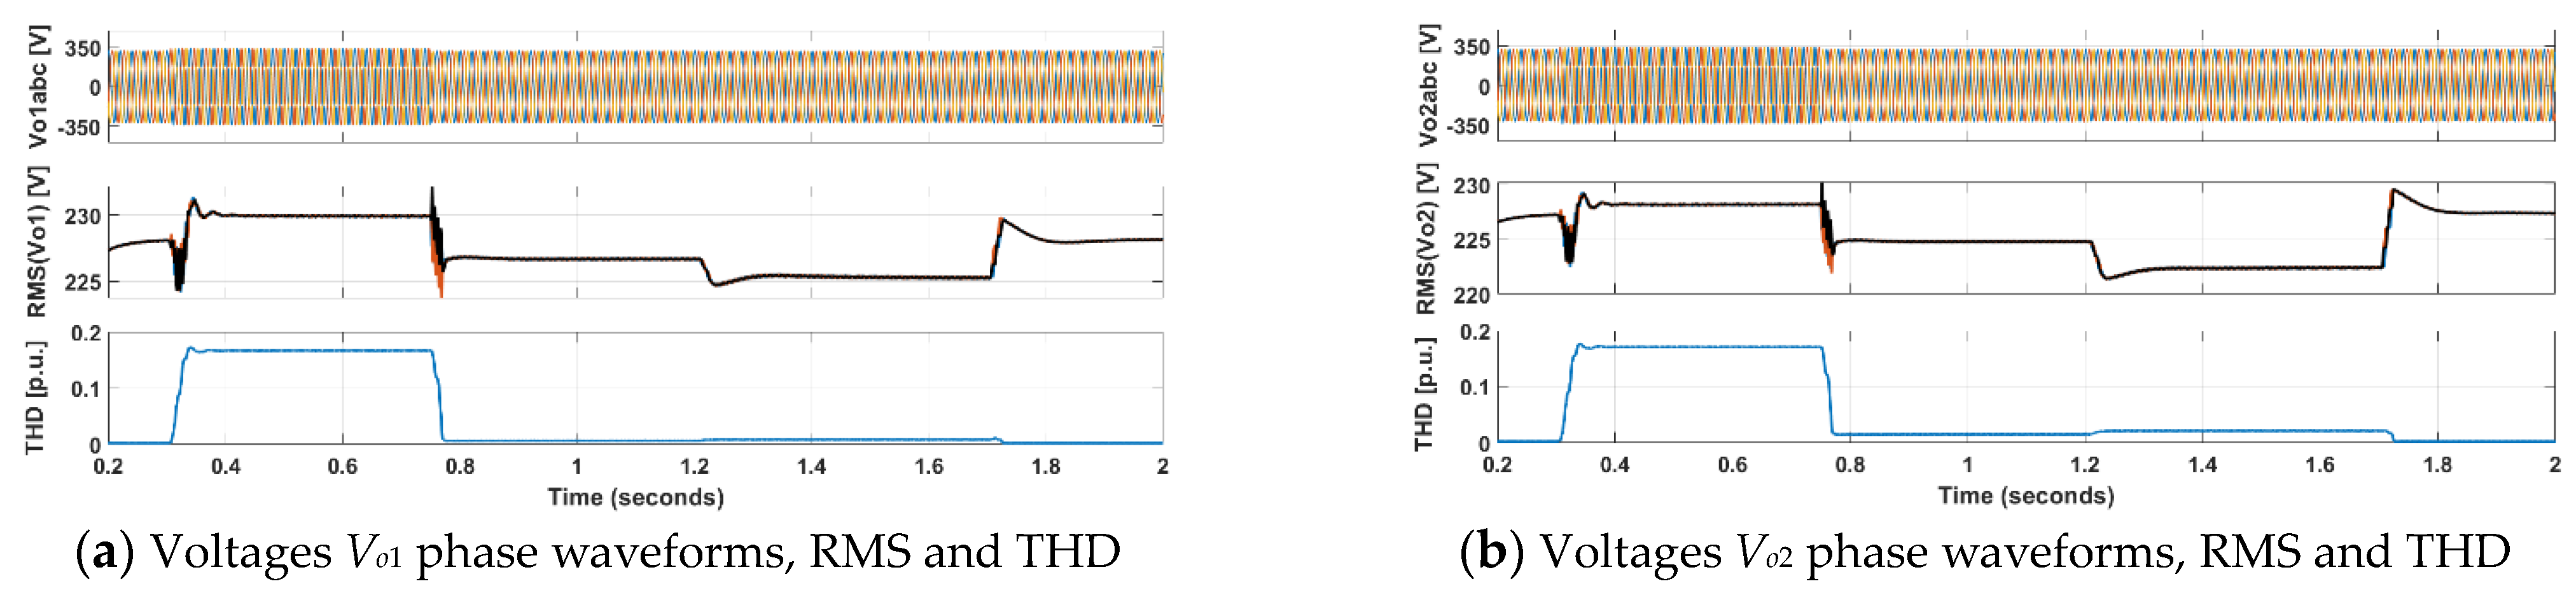
In Figure 8, voltages Vo1 and Vo2 are shown. From their RMS values, it can be seen that the voltage drop is less than 10 V. At the beginning, THD is very small, around 1%. Then, when non-linear Load 2 (three-phase rectifier is plugged in, it rises to 18% for Vo1 and 16% for Vo1. With the start of harmonic compensation, THD falls to a couple percent. When non-linear Load 2 is plugged in at the moment of 1.2 s, THD rises slightly since the compensation is still active.
Figure 8.
Voltages Vo1 and Vo2 three-phase waveforms, their RMS and THD.
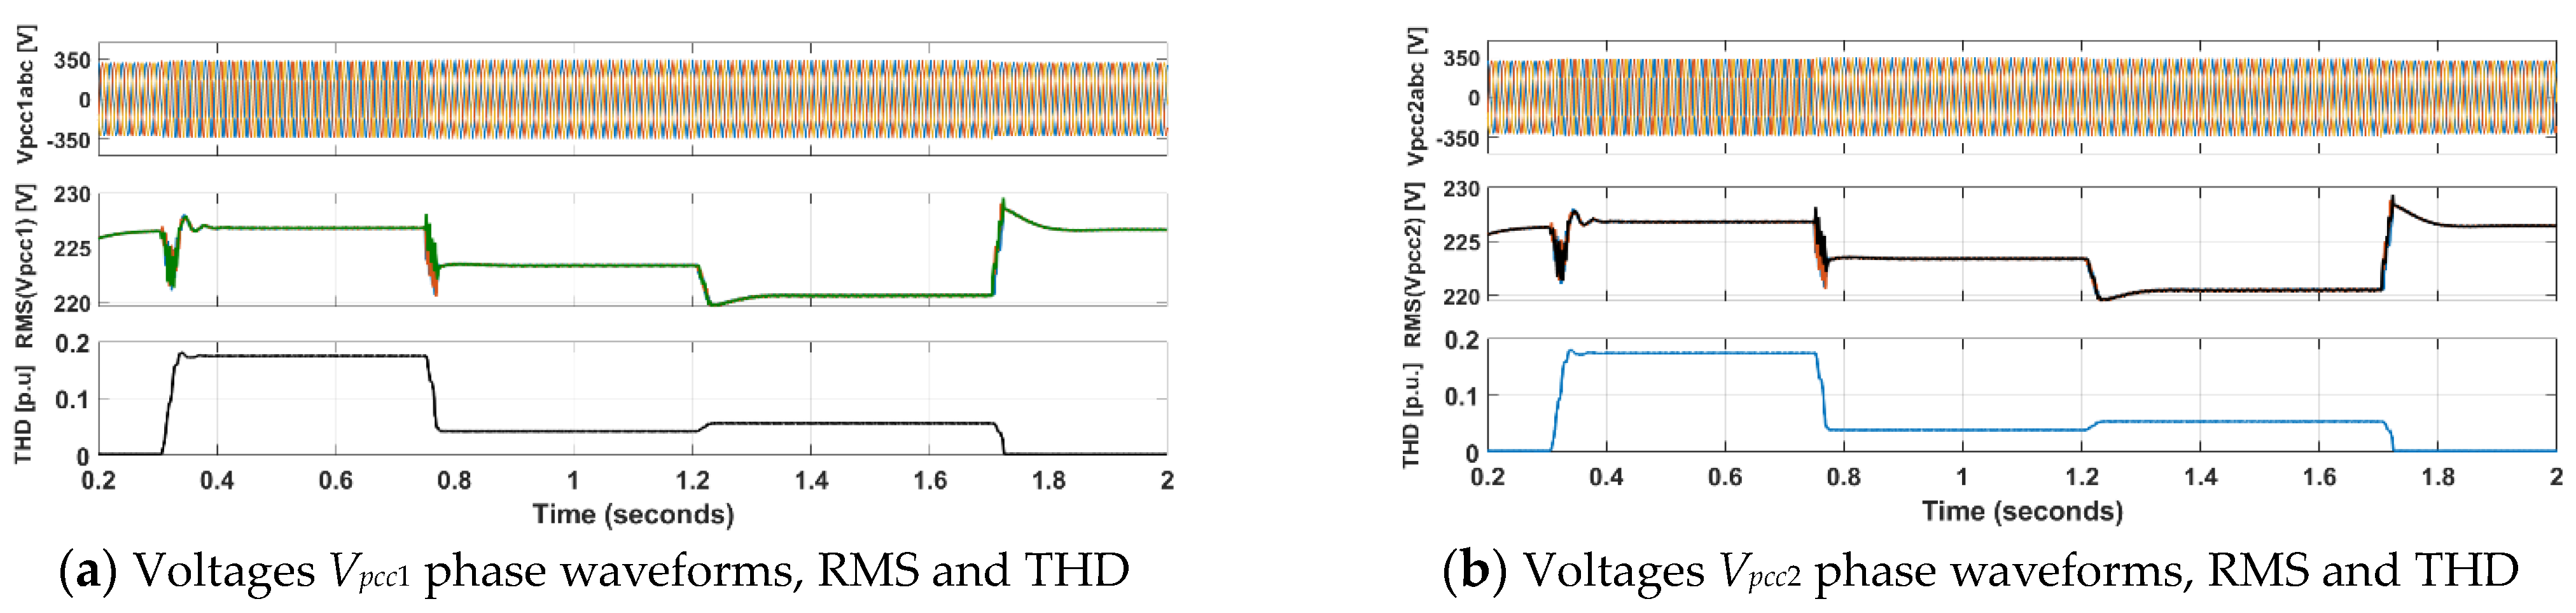
Similar qualitative conclusions can be drawn for voltages in the points of common coupling Vpcc1 and Vpcc2 (Figure 9), with the difference that points of common coupling are a feeder away from the inverters and therefore they experience somewhat higher voltage drop and THD in the whole process.
Figure 9.
Voltages Vpcc1 and Vpcc2 three-phase waveforms, their RMS and THD.
However, THD is less than 8% when both non-linear loads are connected.
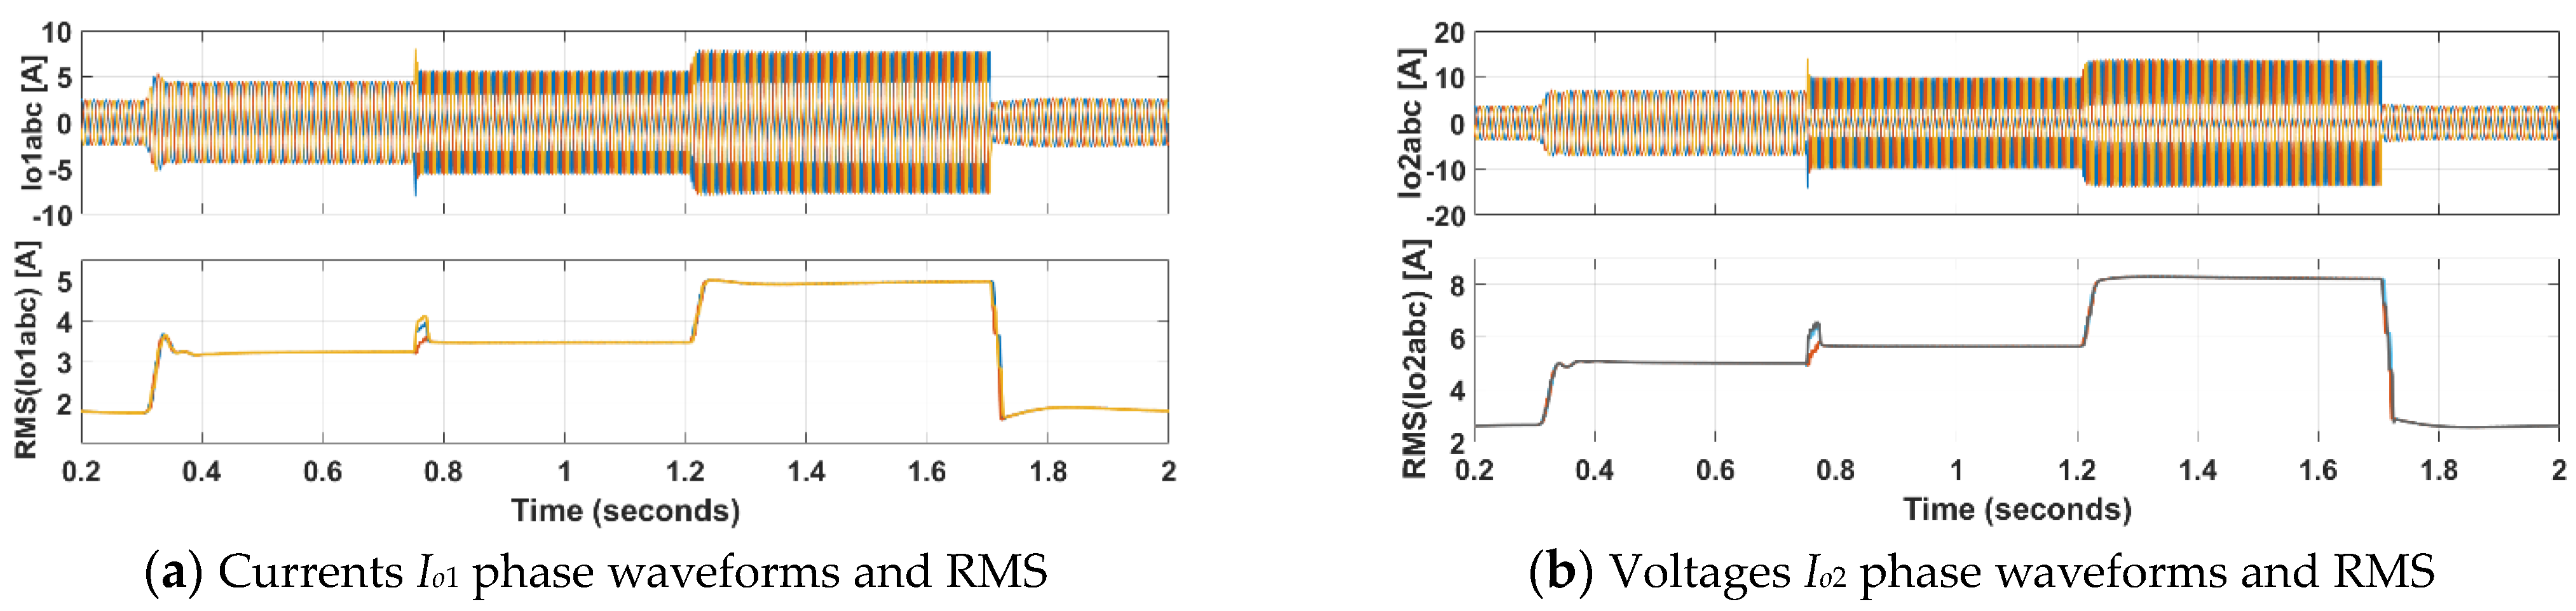
In Figure 10, inverter output currents after filtering, Io1 and Io2 are shown. They generally follow the pattern of respective active power from Figure 7a.
Figure 10.
Currents Io1 and Io2 three-phase waveforms, their RMS and THD.
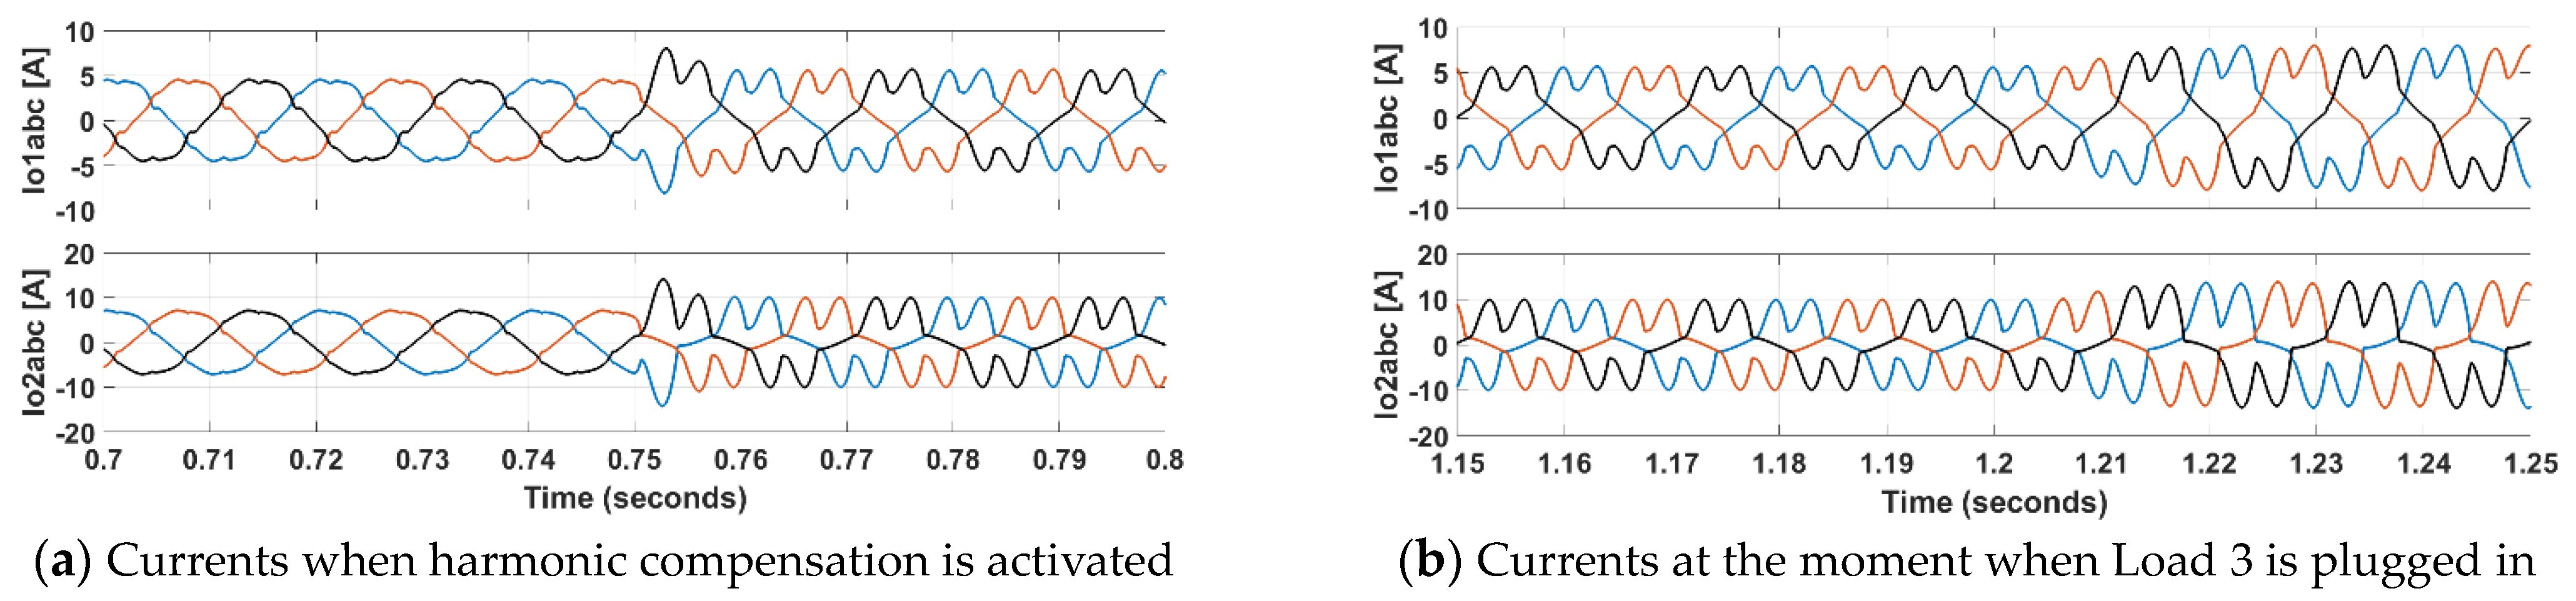
Figure 11 presents two details from Figure 10 around the moment of 0.7 s when the harmonic compensation is activated and another detail around the moment of 1.2 s when a non-linear load, Load 3, is plugged in, while compensation is still on. It is noticeable that the current waveform deteriorates further at the moment of starting the harmonic compensation because inverters generate recognizable distorted current components to deal with the rectifier current.
Figure 11.
Currents Io1 and Io2 at moments of interest.
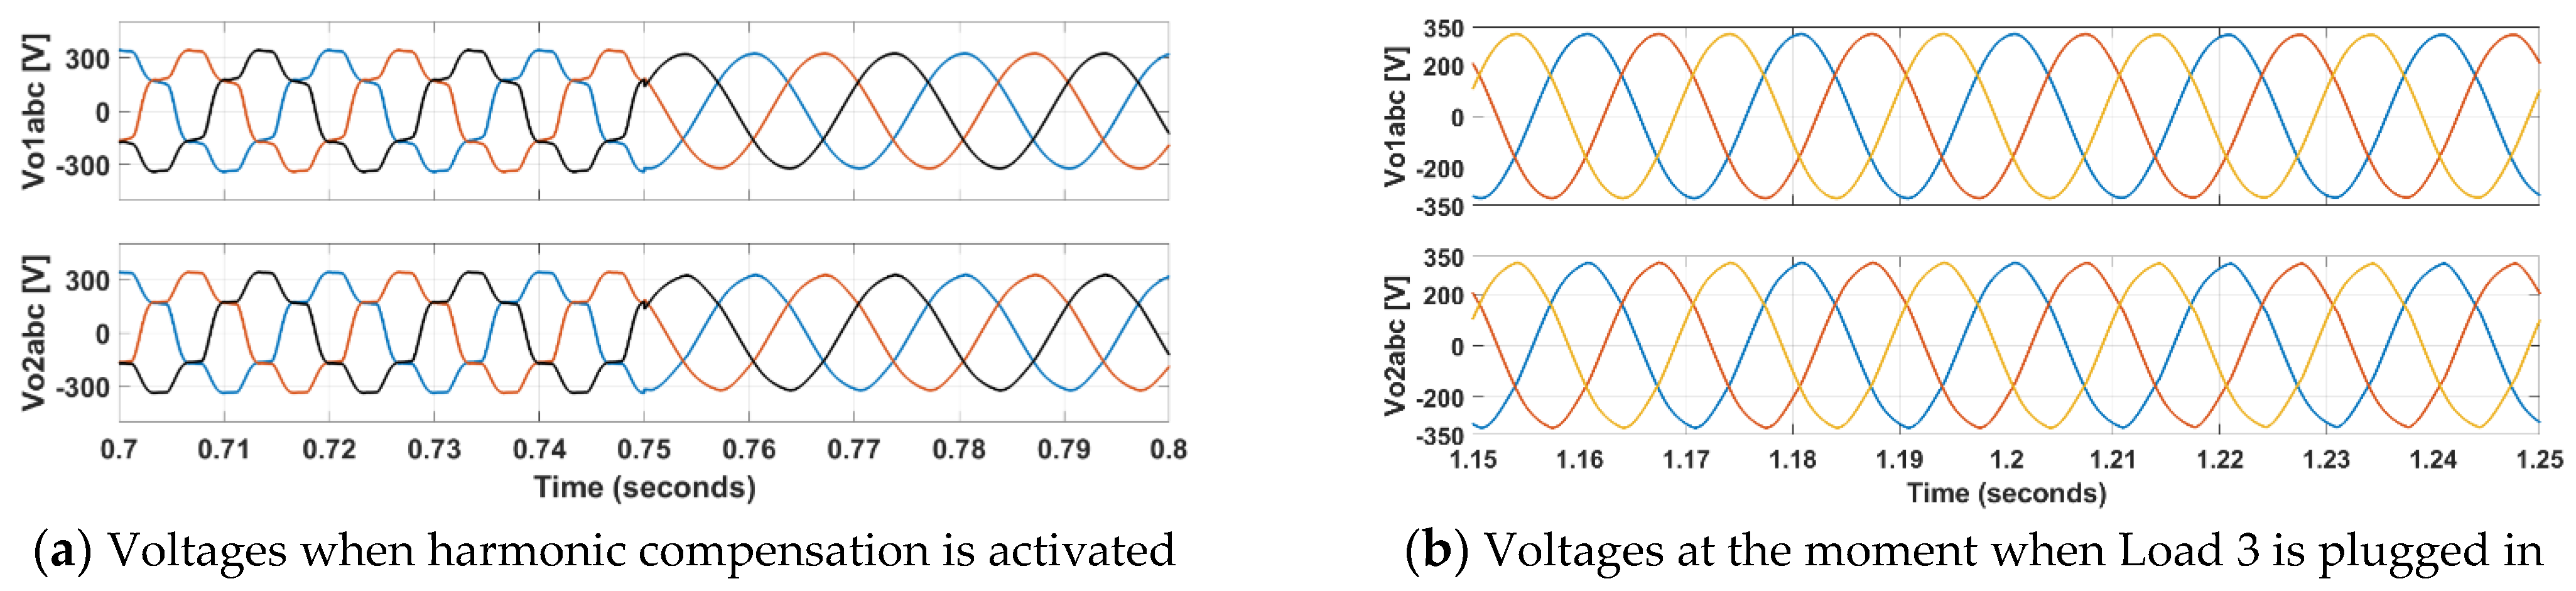
In Figure 12, voltages Vo1 and Vo2 can be observed at the same moments as in Figure 11. Before the harmonic compensation started (Figure 12a), voltages are highly distorted, as already indicated from their THD values (Figure 8). From the moment 0.75 s when harmonic compensation starts, their waveforms are much improved. At the moment of 1.2 s (Figure 12b), a non-linear load, Load 3 is plugged in, which slightly affects waveforms since the compensation is still active.
Figure 12.
Voltages Vo1 and Vo2 at moments of interest.
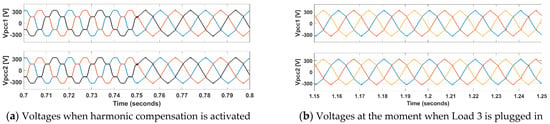
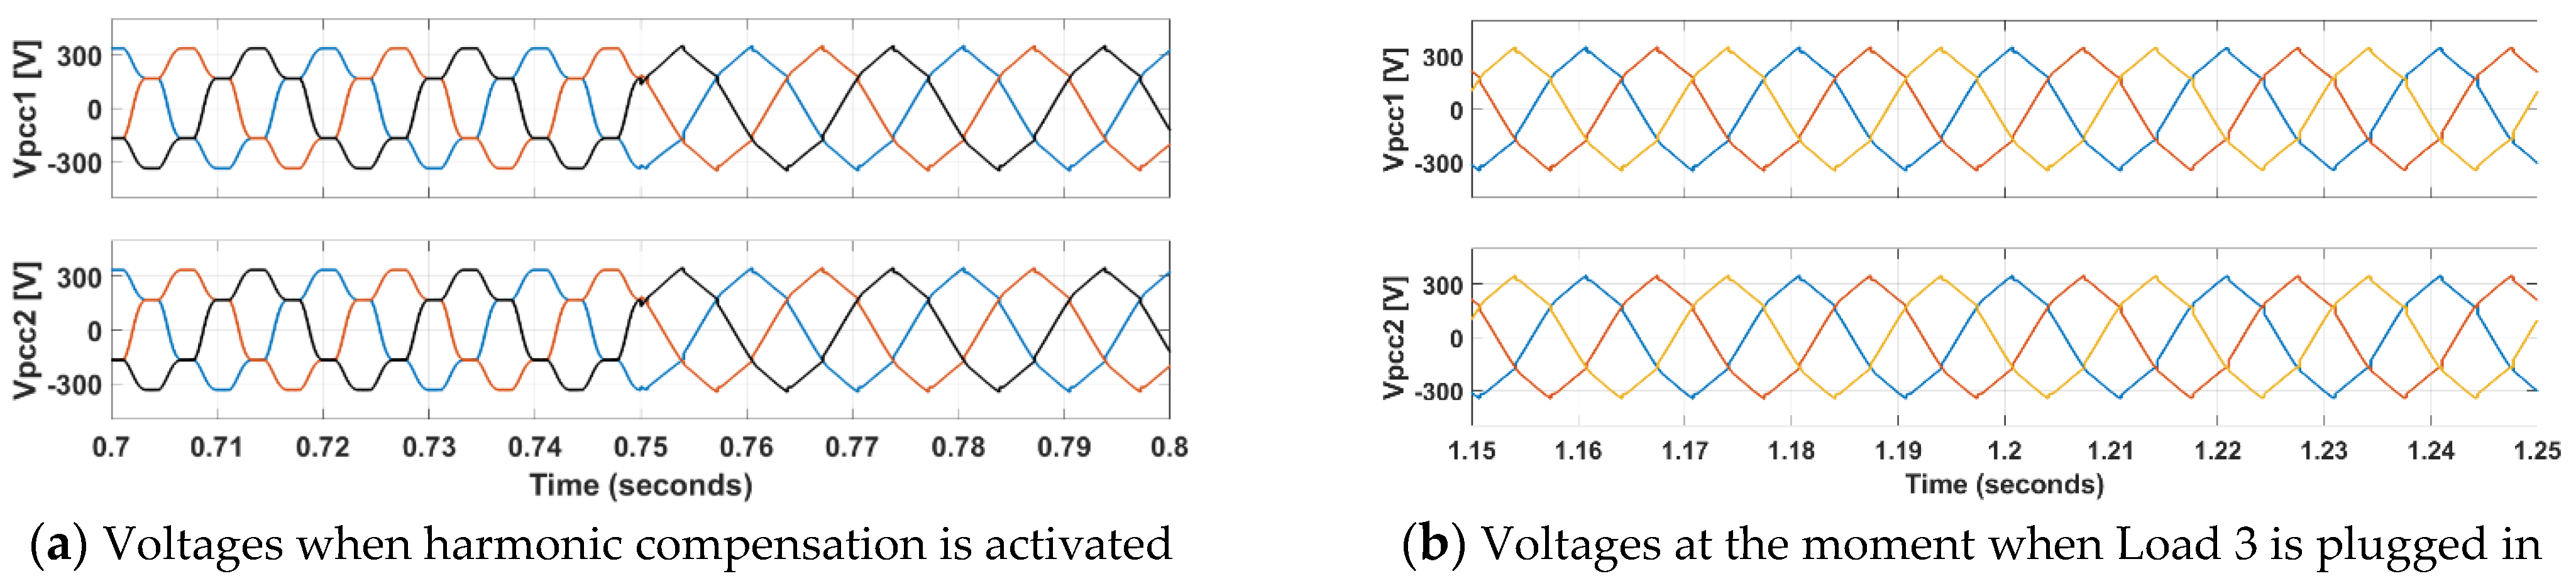
A very similar qualitative analysis applies for voltages of the points of common coupling Vpcc1 and Vpcc2 (Figure 13), with the remark that their waveforms are more distorted since they are a feeder or two away from one or another inverter.
Figure 13.
Voltages Vpcc1 and Vpcc2 at moments of interest.
5. Conclusions
This paper proposes a goal function-based decentralized control of microgrids with an arbitrary X/R feeders ratio and grid topology. The proposed approach ensures that the main microgrid stability indicators, voltage and frequency will remain within the predetermined boundaries. Furthermore, an additional goal was set to reduce voltage harmonics in the grid nodes where the grid-tied converters are located. A grid-tied converter as an interface between distribution generation and a grid was controlled in such a way as to compensate for distorted currents produced by non-linear loads, thus improving voltage THD. The priorities of the proposed scheme could be adjusted according to user preferences. Although the proposed derivation of the control law is not trivial, its final form is simple, facilitating simple implementation in practice. The performance of the proposed method was validated through simulations and the results of all relevant indicators. Voltage distortion at the nods where grid-tied inverters are located was reduced decisively, while the microgrid frequency was kept tightly around the pre-set value with a voltage magnitude drop in accordance with the expectations. Similarly, although slightly deteriorated, the situation was at the point of common coupling with loads. In future research, the control law should be extended to include compensation for unbalanced non-linear loads.
Author Contributions
Conceptualization and writing—original draft, M.V.; methodology, M.R.; investigation, I.T.; resources, S.G. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by Ministry of Science, Technological Development and Innovation (Republic of Serbia), Contract No. 451-03-65/2024-03/200156 and by The Faculty of Technical Sciences, University of Novi Sad project: “Scientific and Artistic Research Work of Researchers in Teaching and Associate Positions at the Faculty of Technical Sciences, University of Novi Sad” (No. 01-3394/1).
Data Availability Statement
The original contributions presented in the study are included in the article, further inquiries can be directed to the corresponding author/s.
Conflicts of Interest
The authors declare no conflict of interest.
Appendix A
It will be proved here that the proposed decentralized control strategy guarantees the boundedness of both voltage and frequency deviation, as well as the boundedness of harmonic distortions H.
Recall that the local goal function for node is defined in (21) as
where subscripts denoting the node index are now written explicitly. We emulate the procedure previously published in [33] and define the total goal function as
We will proceed to show that under the proposed control law, is negative implying that is a monotonously non-increasing function of time, which in turn implies that the relevant variables will remain bounded.
Recognizing that the proposed control law can be expressed as
where and are defined in [33], we conclude that
Following the same procedure as in [33], we see that the total goal function can be expressed as
where
From this, it can be readily concluded that will be negative (and consequently will be decreasing) whenever
Let be an upper bound on , i.e., let This upper limit may be unknown, but we do know that it exists. Let us choose and such that whenever and at any node , becomes greater than . Since is unbounded, again we know that such and do indeed exists. Let us further choose such that .
By construction, whenever the value of the goal function reaches beyond , the derivative of will become negative, and will decrease. Therefore, the value of will always remain bounded, and consequently, the voltage error at each node will remain smaller than .
References
- Lasseter, R.; Akhil, A.; Marnay, C.; Stephens, J.; Dagle, J.; Guttromson, R.; Meliopoulous, A.S.; Yinger, R.; Eto, J. White Paper on Integration of Distributed Energy Resources. The CERTS Microgrid Concept; Consortium for Electric Reliability Technology Solutions: Berkeley, CA, USA, 2002; pp. 1–27.
- Villeneuve, P.L. Concerns generated by islanding. IEEE Power Energy Mag. 2004, 2, 49–53. [Google Scholar] [CrossRef]
- Khan, I.; Vijay, A.S.; Doolla, S. Nonlinear load harmonic mitigation strategies in microgrids: State of the art. IEEE Syst. J. 2022, 16, 4243–4255. [Google Scholar] [CrossRef] [Scilit]
- Razmi, D.; Lu, T.; Papari, B.; Akbari, E.; Fathi, G.; Ghadamyari, M. An overview on power quality issues and control strategies for distribution networks with the presence of distributed generation resources. IEEE Access 2023, 8, 10308–10325. [Google Scholar] [CrossRef] [Scilit]
- Elmetwaly, A.H.; Eldesouky, A.A.; Sallam, A.A. An adaptive D-FACTS for power quality enhancement in an isolated microgrid. IEEE Access 2020, 8, 57923–57942. [Google Scholar] [CrossRef] [Scilit]
- Bagheri, M.; Nurmanova, V.; Abedinia, O.; Naderi, M.S. Enhancing power quality in microgrids with a new online control strategy for DSTATCOM using reinforcement learning algorithm. IEEE Access 2018, 6, 38986–38996. [Google Scholar] [CrossRef] [Scilit]
- Khorsavi, N.; Abdolmohammadi, H.R.; Bagheri, S.; Miveh, M.R. A novel control approach for harmonic compensation using switched power filter compensators in micro-grids. IET Renew. Power Gener. 2021, 15, 3989–4005. [Google Scholar]
- Khorsavi, N.; Echalih, R.B.; Bagheri, S.; Hekss, Z.; Hassani, R.; Messaoudi, M. Enhancement of power quality issues for a hybrid AC/DC microgrid based on optimization methods. IET Renew. Power Gener. 2022, 16, 1773–1791. [Google Scholar]
- Hashempour, M.M.; Savaghebi, M.J.; Vasquez, C.; Guerrero, J.M. A control architecture to coordinate distributed generators and active power filters coexisting in a microgrid. IEEE Trans. Smart Grid 2016, 7, 2325–2336. [Google Scholar] [CrossRef] [Scilit]
- Lai, J.C.-T.; Chung, H.S.-H.; He, Y.; Wu, W.; Blaabjerg, F. Wideband series harmonic voltage compensator for enhancing stability of microgrids. IEEE Trans. Power Electron. 2022, 37, 9687–9702. [Google Scholar] [CrossRef] [Scilit]
- Savaghebi, M.; Jalilian, A.; Vasquez, J.C.; Guerrero, J.M. Secondary control scheme for voltage unbalance compensation in an islanded droop-controlled microgrid. IEEE Trans. Smart Grid 2012, 3, 797–807. [Google Scholar] [CrossRef] [Scilit]
- Zeng, Z.; Yang, H.; Tang, S.; Zhao, R. Objective-oriented power quality compensation of multifunctional grid-tied inverters and its application in micro-grids. IEEE Trans. Power Electron. 2015, 30, 1255–1265. [Google Scholar] [CrossRef] [Scilit]
- Liu, J.; Taghizadeh, S.; Lu, J.; Hossain, M.J.; Stegen, S.; Li, H. Three-phase four-wire interlinking converter with enhanced power quality improvement in microgrid systems. CSEE J. Power Energy Syst. 2021, 7, 1064–1077. [Google Scholar]
- Adineh, B.; Keypour, R.; Davari, P.; Blaabjerg, F. Review of harmonic mitigation methods in microgrid: From a hierarchical control perspective. IEEE J. Emerg. Sel. Top. Power Electron. 2021, 9, 3044–3060. [Google Scholar] [CrossRef] [Scilit]
- Cheng, P.-T.; Chen, C.-A.; Lee, T.-L.; Kuo, S.-Y. A cooperative imbalance compensation method for distributed-generation interface converters. IEEE Trans. Ind. Appl. 2009, 45, 805–815. [Google Scholar] [CrossRef] [Scilit]
- Kordkheili, H.H.; Banejad, M.; Guerrero, J.M.; Kalat, A.A. Primary control design based on capacity curves for inverter-based microgrids. Electr. Power Compon. Syst. 2018, 46, 1147–1159. [Google Scholar] [CrossRef] [Scilit]
- Moussa, H.; Shahin, A.; Martin, J.-P.; Nahid-Mobarakeh, B.; Pierfederici, S.; Moubayed, N. Harmonic power sharing with voltage distortion compensation of droop controlled islanded microgrids. IEEE Trans. Smart Grid 2018, 9, 5335–5347. [Google Scholar] [CrossRef] [Scilit]
- Moussa, H.; Martin, J.-P.; Pierfederici, S.; Meibody-Tabar, F.; Moubayed, N. Voltage harmonic distortion compensation with non-linear load power sharing in low-voltage islanded microgrid. Math. Comput. Simul. 2019, 158, 32–48. [Google Scholar] [CrossRef] [Scilit]
- Göthner, F.; Roldán-Pérez, J.; Torres-Olguin, R.E.; Midtgård, O.-M. Harmonic Virtual Impedance Design for Optimal Management of Power Quality in Microgrids. IEEE Trans. Power Electron. 2021, 36, 10114–10126. [Google Scholar] [CrossRef] [Scilit]
- Keyvani-Boroujeni, B.; Fani, B.; Shahgholian, G.; Alhelou, H.H. Virtual Impedance-Based Droop Control Scheme to Avoid Power Quality and Stability Problems in VSI-Dominated Microgrids. IEEE Access 2021, 9, 144999–145011. [Google Scholar] [CrossRef] [Scilit]
- Hoang, T.V.; Lee, H.-H. Virtual Impedance Control Scheme to Compensate for Voltage Harmonics with Accurate Harmonic Power Sharing in Islanded Microgrids. IEEE J. Emerg. Technol. 2021, 9, 1682–1695. [Google Scholar] [CrossRef] [Scilit]
- Lou, G.; Li, S.; Gu, W.; Yang, Q. Distributed Harmonic Power Sharing with Voltage Distortion Suppression in Islanded Microgrids Considering Non-linear Loads. CSEE J. Power Energy Syst. 2024, 10, 117–128. [Google Scholar]
- Wang, Z.; Chen, Y.; Li, X.; Xu, Y.; Wu, W.; Liao, S.; Wang, H.; Cao, S. Adaptive Harmonic Impedance Reshaping Control Strategy Based on a Consensus Algorithm for Harmonic Sharing and Power Quality Improvement in Microgrids with Complex Feeder Networks. IEEE Trans. Smart Grid 2022, 13, 47–57. [Google Scholar] [CrossRef] [Scilit]
- Liu, B.; Liu, Z.; Liu, J. A Noninvasive Feeder Impedance Estimation Method for Parallel Inverters in Microgrid Based on Load Harmonic Current. IEEE Trans. Power Electron. 2021, 36, 7354–7359. [Google Scholar] [CrossRef] [Scilit]
- Sreekumar, P.; Khadkikar, V. Direct Control of the Inverter Impedance to Achieve Controllable Harmonic Sharing in the Islanded Microgrid. IEEE Trans. Ind. Electron. 2016, 64, 827–837. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.; Yi, H.; Wen, Y.; Wang, Z.; Li, Q.; Kang, F.; Zhuo, F. A Decentralized Nonlinear Harmonic Power Sharing Scheme Considering Harmonic Residual Capacity and Working Conditions of Fundamental Load. IEEE Trans. Power Electron. 2024, 39, 14533–14549. [Google Scholar] [CrossRef] [Scilit]
- Li, G.; Song, W.; Liu, W. A Quasi-Harmonic Voltage Feedforward Control for Improving Power Quality in VSG-Based Islanded Microgrid. IEEE J. Emerg. Sel. Top. Power Electron. 2024, 12, 2994–3004. [Google Scholar] [CrossRef] [Scilit]
- Li, S.; Wu, J.; Agundis-Tinajero, G.D.; Chaudhary, S.K.; Vasquez, J.C.; Guerrero, J.M. A Decomposed Harmonic Current Suppression Method for VSG-Based Microgrids Connected to Distorted Grids. IEEE Trans. Ind. Electron. 2024, 71, 10669–10680. [Google Scholar] [CrossRef] [Scilit]
- Nandi, R.; Tripathy, M.; Gupta, C.P. Multi-Objective Optimization Based Voltage Injection Technique for Minimizing Imbalance and Harmonics in AC Microgrid. IEEE Trans. Sustain. Energy 2024, 15, 1269–1287. [Google Scholar] [CrossRef] [Scilit]
- Santos Alonso, A.M.; Brandao, D.I.; Caldognetto, T.; Marafão, F.P.; Mattavelli, P. A selective harmonic compensation and power control approach exploiting distributed electronic converters in microgrids. Int. J. Electr. Power Energy Syst. 2020, 115, 105452. [Google Scholar] [CrossRef] [Scilit]
- Samanta, I.S.; Panda, S.; Rout, P.K.; Bajaj, M.; Piecha, M.; Blazek, V.; Prokop, L. A Comprehensive Review of Deep-Learning Applications to Power Quality Analysis. Energies 2023, 16, 4406. [Google Scholar] [CrossRef] [Scilit]
- Awais, M.; Khan, L.; Khan, S.G.; Awais, Q.; Jamil, M. Adaptive Neural Network Q-Learning-Based Full Recurrent Adaptive NeuroFuzzy Nonlinear Control Paradigms for Bidirectional-Interlinking Converter in a Grid-Connected Hybrid AC-DC Microgrid. Energies 2023, 16, 1902. [Google Scholar] [CrossRef] [Scilit]
- Isakov, I.; Vekić, M.; Rapaić, M.; Todorović, I.; Grabić, S. Decentralized Self-Stabilizing Primary Control of Microgrids. Int. J. Electr. Power Energy Syst. 2024, 155, 109477. [Google Scholar] [CrossRef] [Scilit]
- von Meier, A. Electric Power Systems, A Conceptual Introduction; IEEE Press: Piscataway, NJ, USA; Wiley–Interscience: Hoboken, NJ, USA, 2006; ISBN 0-471-17859-4. [Google Scholar]
- Vekić, M.; Isakov, I.; Rapaić, M.; Grabić, S.; Todorović, I.; Porobić, V. Decentralized microgrid control “beyond droop”. In Proceedings of the 2022 IEEE PES Innovative Smart Grid Technologies Conference Europe (ISGT-Europe), Novi Sad, Serbia, 10–12 October 2022; pp. 1–5. [Google Scholar]
- Arrillaga, J.; Watson, N.R. Power System Harmonics, 2nd ed.; Wiley: Hoboken, NJ, USA, 2003; ISBN 9780470851296. [Google Scholar]
- Guerrero, J.M.; Matas, J.; de Vicuna, L.G.; Castilla, M.; Miret, J. Decentralized Control for Parallel Operation of Distributed Generation Inverters Using Resistive Output Impedance. IEEE Trans. Ind. Electron. 2007, 54, 994–1004. [Google Scholar] [CrossRef] [Scilit]
- He, J.; Li, Y.W. Analysis and design of interfacing inverter output virtual impedance in a low voltage microgrid. In Proceedings of the 2010 IEEE Energy Conversion Congress and Exposition, Atlanta, GA, USA, 12–16 September 2010; pp. 2857–2864. [Google Scholar]
- Eberlein, S.; Rudion, K. Small-signal stability modelling, sensitivity analysis and optimization of droop controlled inverters in LV microgrids. Int. J. Electr. Power Energy Syst. 2021, 125, 106404. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).