Precision Controllable Reversible Watermarking Algorithm for Oblique Photography 3D Models


Abstract
1. Introduction
2. Preliminary
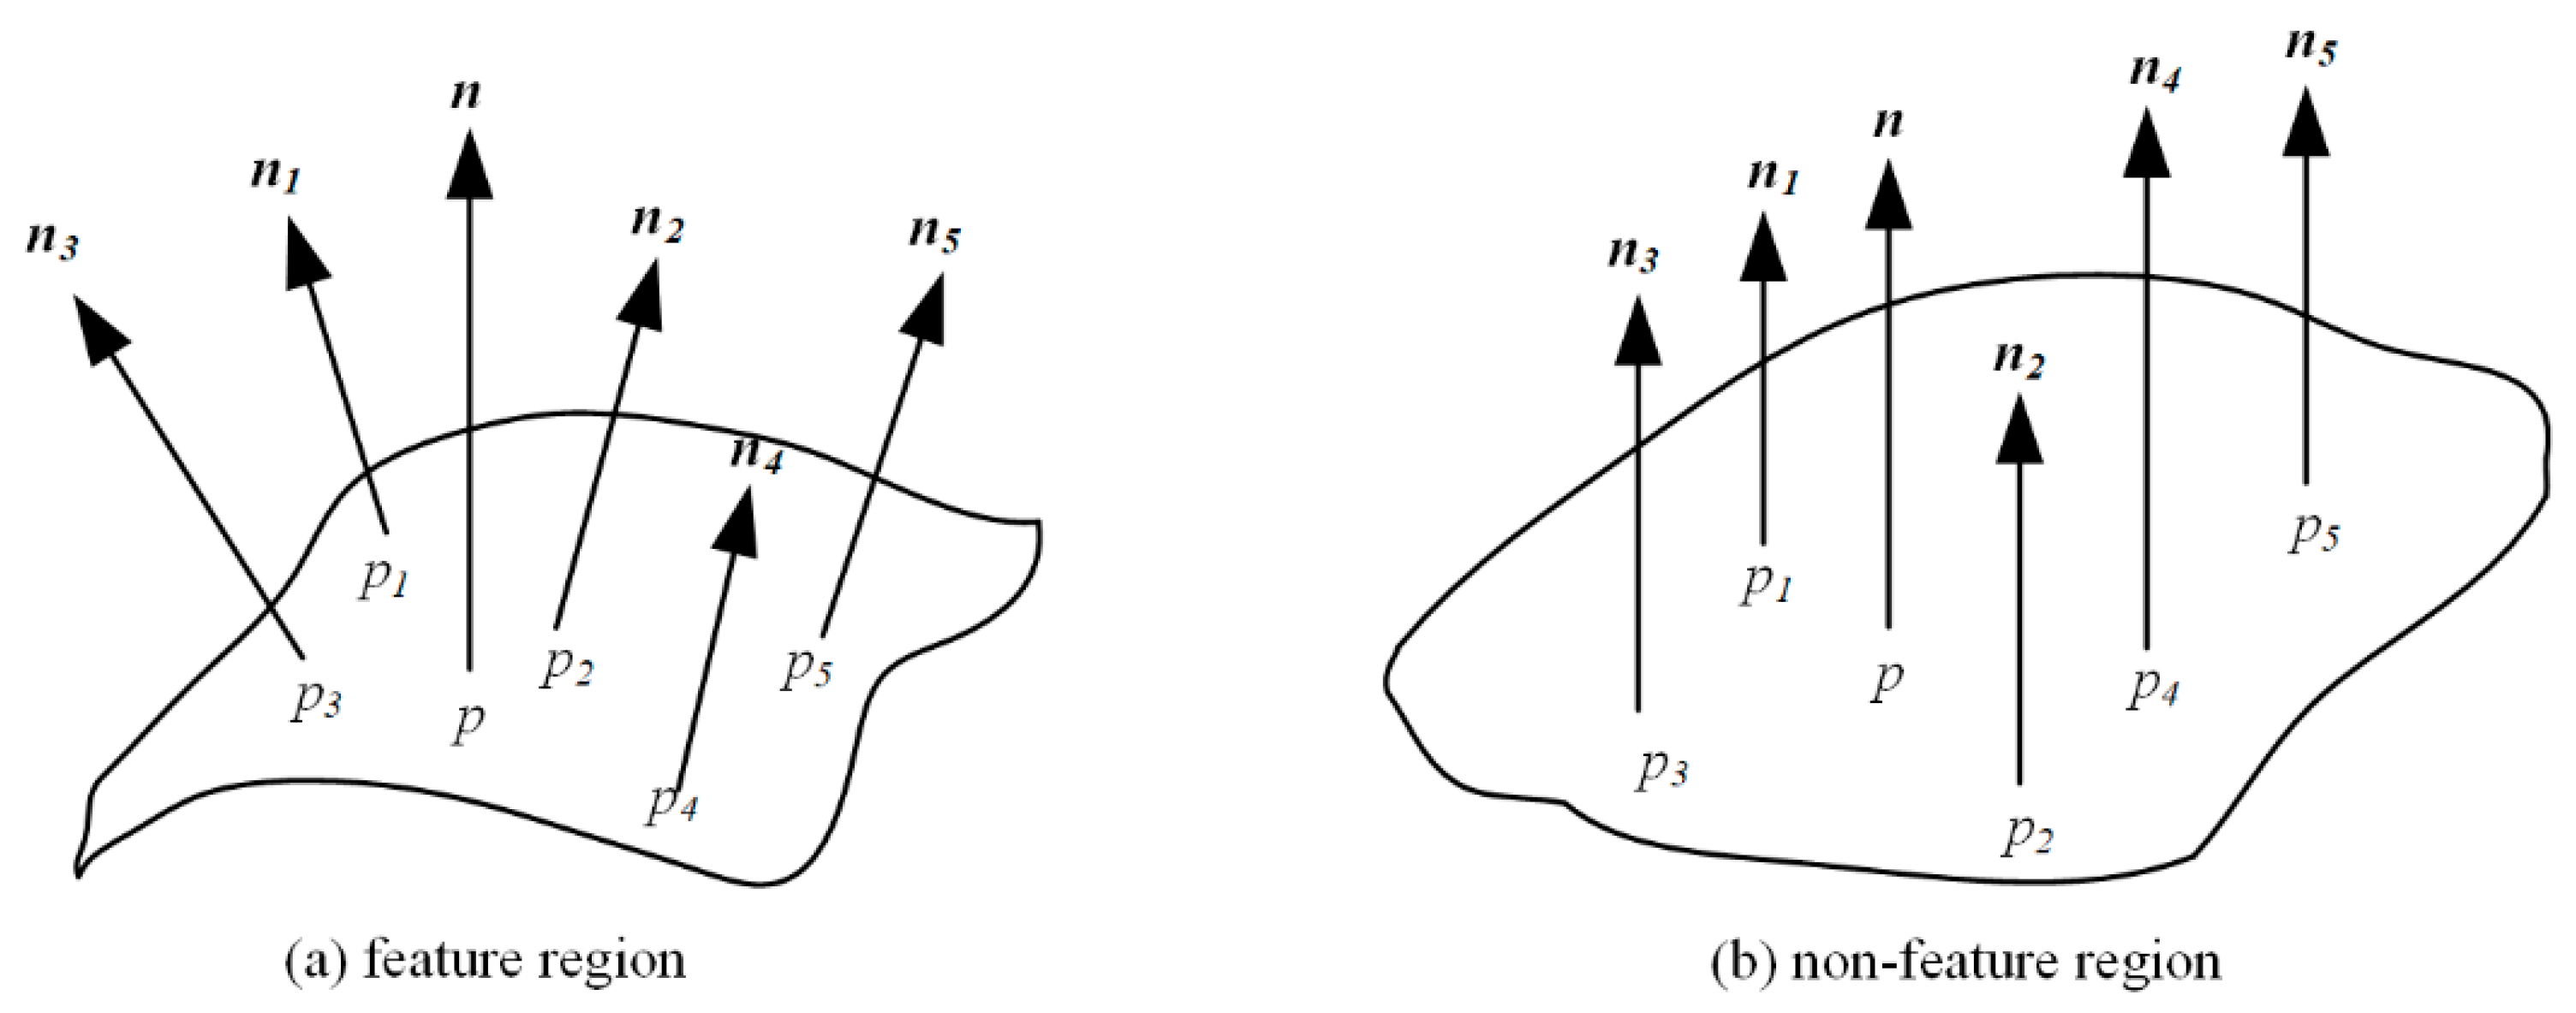
2.1. Feature Point Extraction
2.2. Vertex Grouping
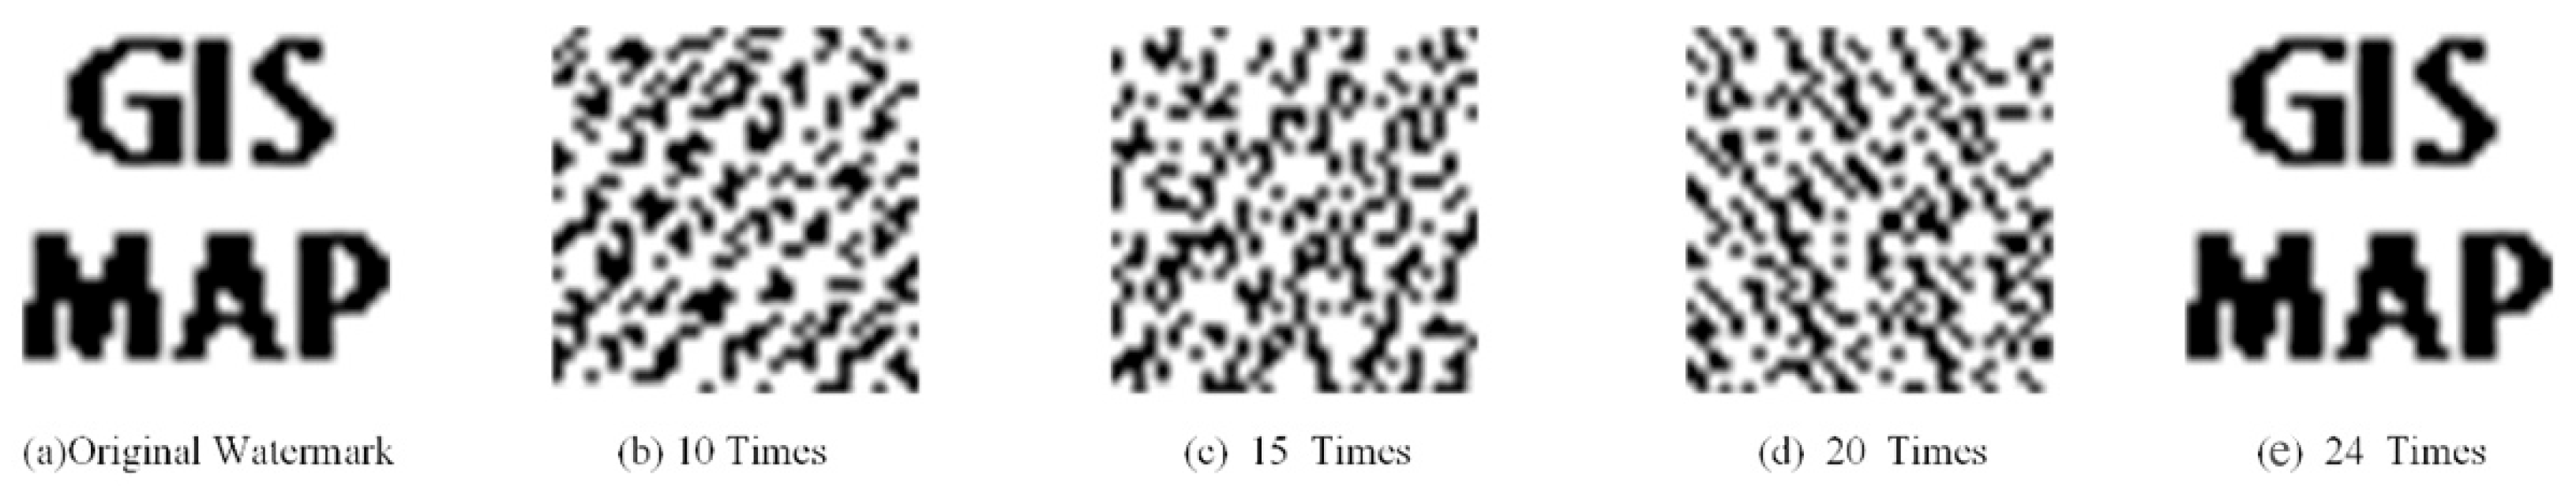
2.3. Watermark Image Arnold Scrambling
3. The Proposed Algorithm
- (1)
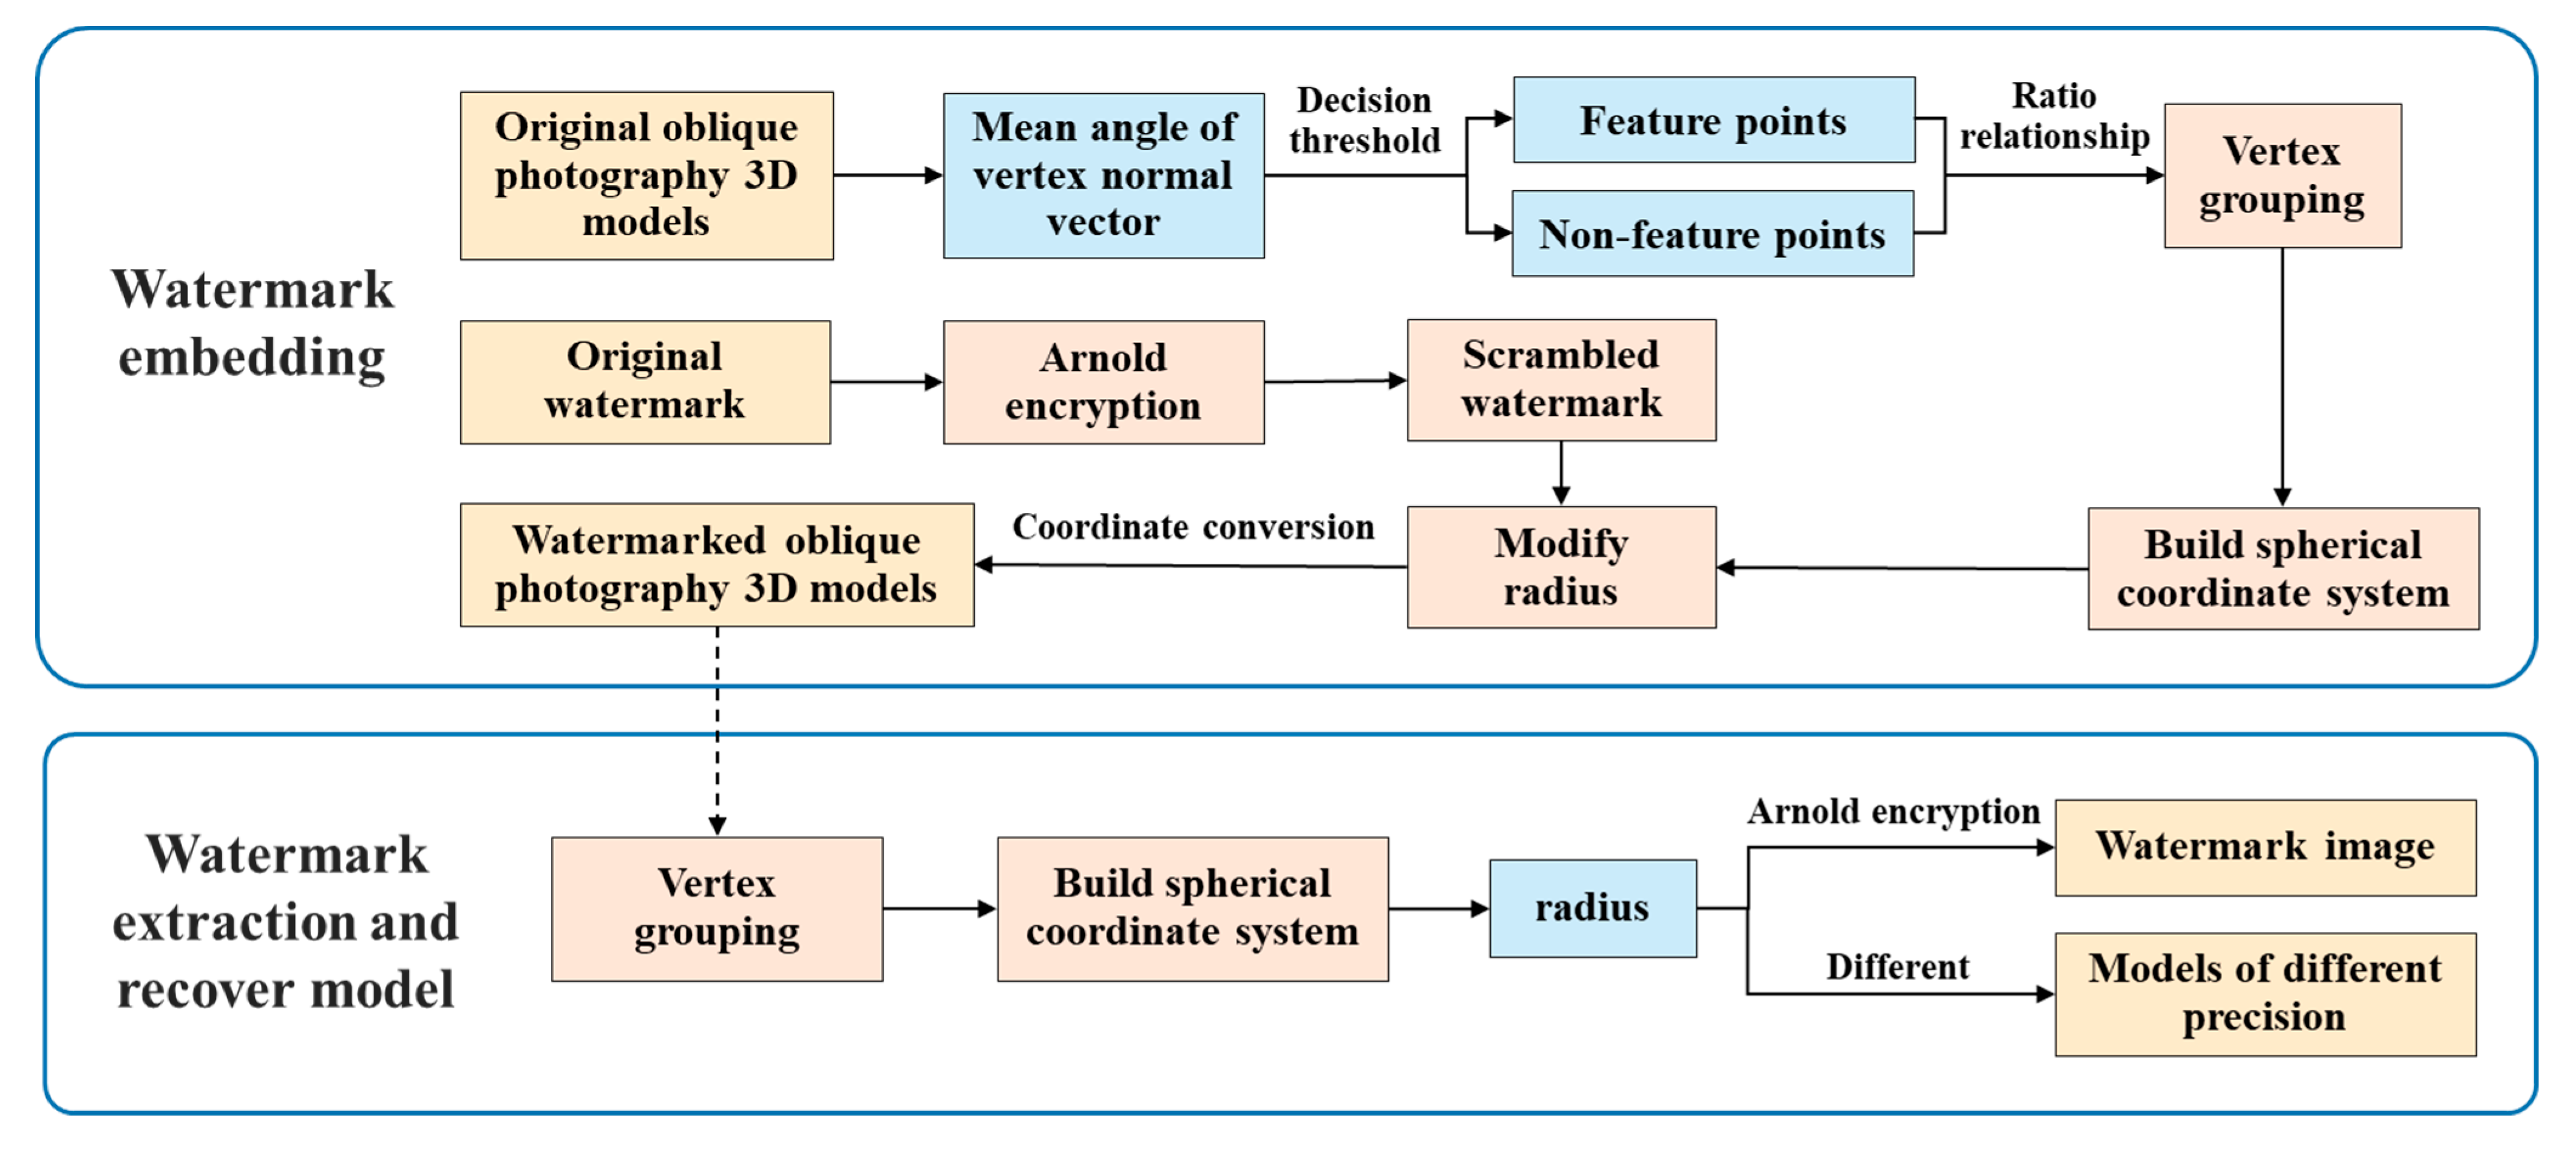
- Watermark embedding stage. First, the watermark image is preprocessed by Arnold transform. Secondly, feature points are extracted based on the mean angle between the vertex normal vectors. Then the distance ratio between feature points and non-feature points is divided into groups, and the spherical coordinate system of the two types of points is constructed in the groups. Finally, the scrambled watermark information is embedded into the 3D models by modifying the radius of the spherical coordinate system;
- (2)
- Watermark extraction and model recovery stage. The data processing process is consistent with the early stage of embedding. The spherical coordinates are obtained by obtaining the grouping and conversion calculation of feature points, extracting the watermark using the obtained radius value, and then restoring the original model through different radius values obtained from different positions. The detailed flowchart of this algorithm is depicted in Figure 3.
3.1. Watermark Embedding Algorithm
3.2. Watermark Extraction Algorithm
3.3. Recover Model Algorithm
4. Experiment and Analysis
4.1. Invisibility Analysis
4.1.1. Subjective Visual Analysis
4.1.2. Objective Indicator Analysis
4.2. Robustness of the Watermarking Scheme
4.2.1. Geometrical Attacks
4.2.2. Cropping Attacks
4.2.3. Simplify Attacks
4.2.4. Scaling Attacks
4.2.5. Comparative Analysis of Robustness
4.3. Reversibility Analysis
4.4. Precision Control Analysis
5. Large 3D Model Scene Discussion
5.1. Performance Analysis
5.2. Efficiency Analysis
6. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Yu, K.; Li, H.; Xing, L.; Wen, T.; Fu, D.; Yang, Y.; Bai, H. Scene-aware refinement network for unsupervised monocular depth estimation in ultra-low altitude oblique photography of UAV. ISPRS J. Photogramm. Remote Sens. 2023, 205, 284–300. [Google Scholar] [CrossRef] [Scilit]
- He, S.; Guo, X.; He, J.; He, J.; Guo, B.; Zheng, C. Investigation of measurement accuracy of bridge deformation using UAV-based oblique photography technique. Sensors 2022, 22, 6822. [Google Scholar] [CrossRef] [Scilit]
- Qiu, Y.; Jiao, Y.; Luo, J.; Tan, Z.; Huang, L.; Zhao, J.; Xiao, Q.; Duan, H. A rapid water region reconstruction scheme in 3D watershed scene generated by UAV oblique photography. Remote Sens. 2023, 15, 1211. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.; Fan, H.; Kong, G. VGI3D: An interactive and low-cost solution for 3D building modelling from street-level VGI images. J. Geovis. Spat. Anal. 2021, 5, 18. [Google Scholar] [CrossRef] [Scilit]
- Ying, S.; Van, O.P.; Fan, H. New Techniques and Methods for Modelling, Visualization, and Analysis of a 3D City. J. Geovis. Spat. Anal. 2023, 7, 26. [Google Scholar] [CrossRef] [Scilit]
- Lin, M.; Li, F.Y.; Zhou, H. A research on the combination of oblique photography and mobile applications based on the sustainable development of tourism. Sustainability 2020, 12, 3501. [Google Scholar] [CrossRef] [Scilit]
- Mazagol, P.O.; Niogret, P.; Riquier, J.; Depeyre, R.; Ratajczak, R.; Crispim, C.F., Jr.; Tougne, L. Tools against oblivion: 3D visualization of sunken landscapes and cultural heritages applied to a dam reservoir in the Gorges de la Loire (France). J. Geovis. Spat. Anal. 2021, 5, 2. [Google Scholar] [CrossRef] [Scilit]
- Cao, D.; Zhang, B.; Zhang, X.; Yin, L.; Man, X. Optimization methods on dynamic monitoring of mineral reserves for open pit mine based on UAV oblique photogrammetry. Measurement 2023, 207, 112364. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Xiang, H.; Niu, W.; Mao, Z.; Huang, X.; Zhang, X. Oblique photogrammetry supporting procedural tree modeling in urban areas. ISPRS J. Photogramm. Remote Sens. 2023, 200, 120–137. [Google Scholar] [CrossRef] [Scilit]
- Pham, G.N.; Lee, S.H.; Kwon, O.H.; Kwon, K.R. A 3D printing model watermarking algorithm based on 3D slicing and feature points. Electronics 2018, 7, 23. [Google Scholar] [CrossRef] [Scilit]
- Lee, J.; Chen, Y.; Chew, C.; Hung, W.; Fan, Y.; Li, B. Constructing gene features for robust 3D mesh zero-watermarking. J. Inf. Secur. Appl. 2023, 73, 103414. [Google Scholar] [CrossRef] [Scilit]
- Hou, X.; Min, L.; Yang, H. A reversible watermarking scheme for vector maps based on multilevel histogram modification. Symmetry 2018, 10, 397. [Google Scholar] [CrossRef] [Scilit]
- Zhu, C.; Wang, H.; Zhao, Y.; Jiang, X.; Sun, H.; Duan, J.; Li, H.; Huy, L.; Ren, N. Vector map zero-watermarking algorithm considering feature set granularity. J. Inf. Secur. Appl. 2025, 89, 103955. [Google Scholar] [CrossRef] [Scilit]
- Dai, Q.; Wu, B.; Liu, F.; Bu, Z.; Zhang, H. Commutative Encryption and Reversible Watermarking Algorithm for Vector Maps Based on Virtual Coordinates. ISPRS Int. J. Geo-Inf. 2024, 13, 338. [Google Scholar] [CrossRef] [Scilit]
- Ren, N.; Tong, D.; Cui, H.; Zhu, C.; Zhou, Q. Congruence and geometric feature-based commutative encryption-watermarking method for vector maps. Comput. Geosci. 2022, 159, 105009. [Google Scholar] [CrossRef] [Scilit]
- Hou, Z.; Yan, H.; Zhang, L.; Ma, R.; Qu, R.; Yang, B. Zero Watermarking Method based on Multi-channel PCNN and Blockchain for Remote Sensing Image Transaction Certificate and Copyright Protection. IEEE Trans. Geosci. Remote Sens. 2025, 63, 4704415. [Google Scholar] [CrossRef] [Scilit]
- Xu, D.; Ren, N.; Zhu, C. High-resolution remote sensing image zero-watermarking algorithm based on blockchain and sdae. IEEE J. Sel. Top. Appl. Earth Obs. Remote Sens. 2023, 17, 323–339. [Google Scholar] [CrossRef] [Scilit]
- Wang, H.; Jiang, X.; Wang, M.; Zhu, C.; Ren, N.; Hu, L. A Multi-Source Remote Sensing Image Watermarking Model Based on Multi-Domain Generative Adversarial Networks. Appl. Soft Comput. 2025, 184, 113694. [Google Scholar] [CrossRef] [Scilit]
- Chen, W.; Xu, X.; Ren, N.; Zhu, C.; Cai, J. Copyright verification and traceability for remote sensing object detection models via dual model watermarking. Remote Sens. 2025, 17, 481. [Google Scholar] [CrossRef] [Scilit]
- Nan, R.; Zhang, L.; Jin, Y.; Xie, J.; Liu, S.; Wang, H. Robust watermarking algorithm for oblique photography 3D models based on multi-level curvature and weighted distance. Earth Sci. Inform. 2025, 18, 321. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Z.; Zhang, L.; Wang, P.; Zhang, M.; Tan, T. Robust watermarking algorithm based on mahalanobis distance and ISS feature point for 3D point cloud data. Earth Sci. Inform. 2024, 17, 783–796. [Google Scholar] [CrossRef] [Scilit]
- Peng, F.; Qian, W.; Long, M. Visible Reversible Watermarking for 3D Models Based on Mesh Subdivision. In Proceedings of the International Workshop on Digital Watermarking, Melbourne, Australia, 25–27 November 2020; pp. 136–149. [Google Scholar] [CrossRef] [Scilit]
- Qiu, Y.; Gu, H.; Sun, J.; Duan, H.; Luo, J. Rich-information watermarking scheme for 3D models of oblique photography. Multimed. Tools Appl. 2019, 78, 31365–31386. [Google Scholar] [CrossRef] [Scilit]
- Ohbuchi, R.; Masuda, H.; Aono, M. Watermarking three-dimensional polygonal models through geometric and topological modifications. IEEE J. Sel. Areas. Commun. 1998, 16, 551–560. [Google Scholar] [CrossRef] [Scilit]
- Ren, S.; Wang, Z.; Su, D.; Zhang, T.; Mu, D. Information hiding algorithm based on mapping and structure data of 3D model. J. Commun. 2019, 40, 211–222. [Google Scholar] [CrossRef]
- Jiao, Y.; Ma, C.; Luo, J.; Qiu, Y. Security protection of 3d models of oblique photography by digital watermarking and data encryption. Appl. Sci. 2023, 13, 13088. [Google Scholar] [CrossRef] [Scilit]
- Wang, P.C.; Wang, C.M. Reversible data hiding for point-sampled geometry. J. Inf. Sci. Eng. 2007, 23, 1889. [Google Scholar]
- Wang, G.; Ren, N.; Zhu, C.; Jing, M. The Digital Watermarking Algorithm for 3D Models of Oblique Photography. J. Geo-inf. Sci. 2018, 20, 738–743. [Google Scholar] [CrossRef]
- Gong, W.; Zhu, C.; Cui, H.; Ren, N. Digital watermarking algorithm for oblique photography 3D model based on feature line proportion. Sci. Surv. Mapp. 2022, 47, 80–86, 152. [Google Scholar] [CrossRef]
- Wang, P.; Zhang, L.; Wang, S.; Zhang, Z.; Zhang, Q. Reversible Watermarking Algorithm for Oblique Photogrammetry 3D Models with Controllable Accuracy. Geogr. Geo-Inf. Sci. 2024, 40, 1–7. [Google Scholar] [CrossRef]



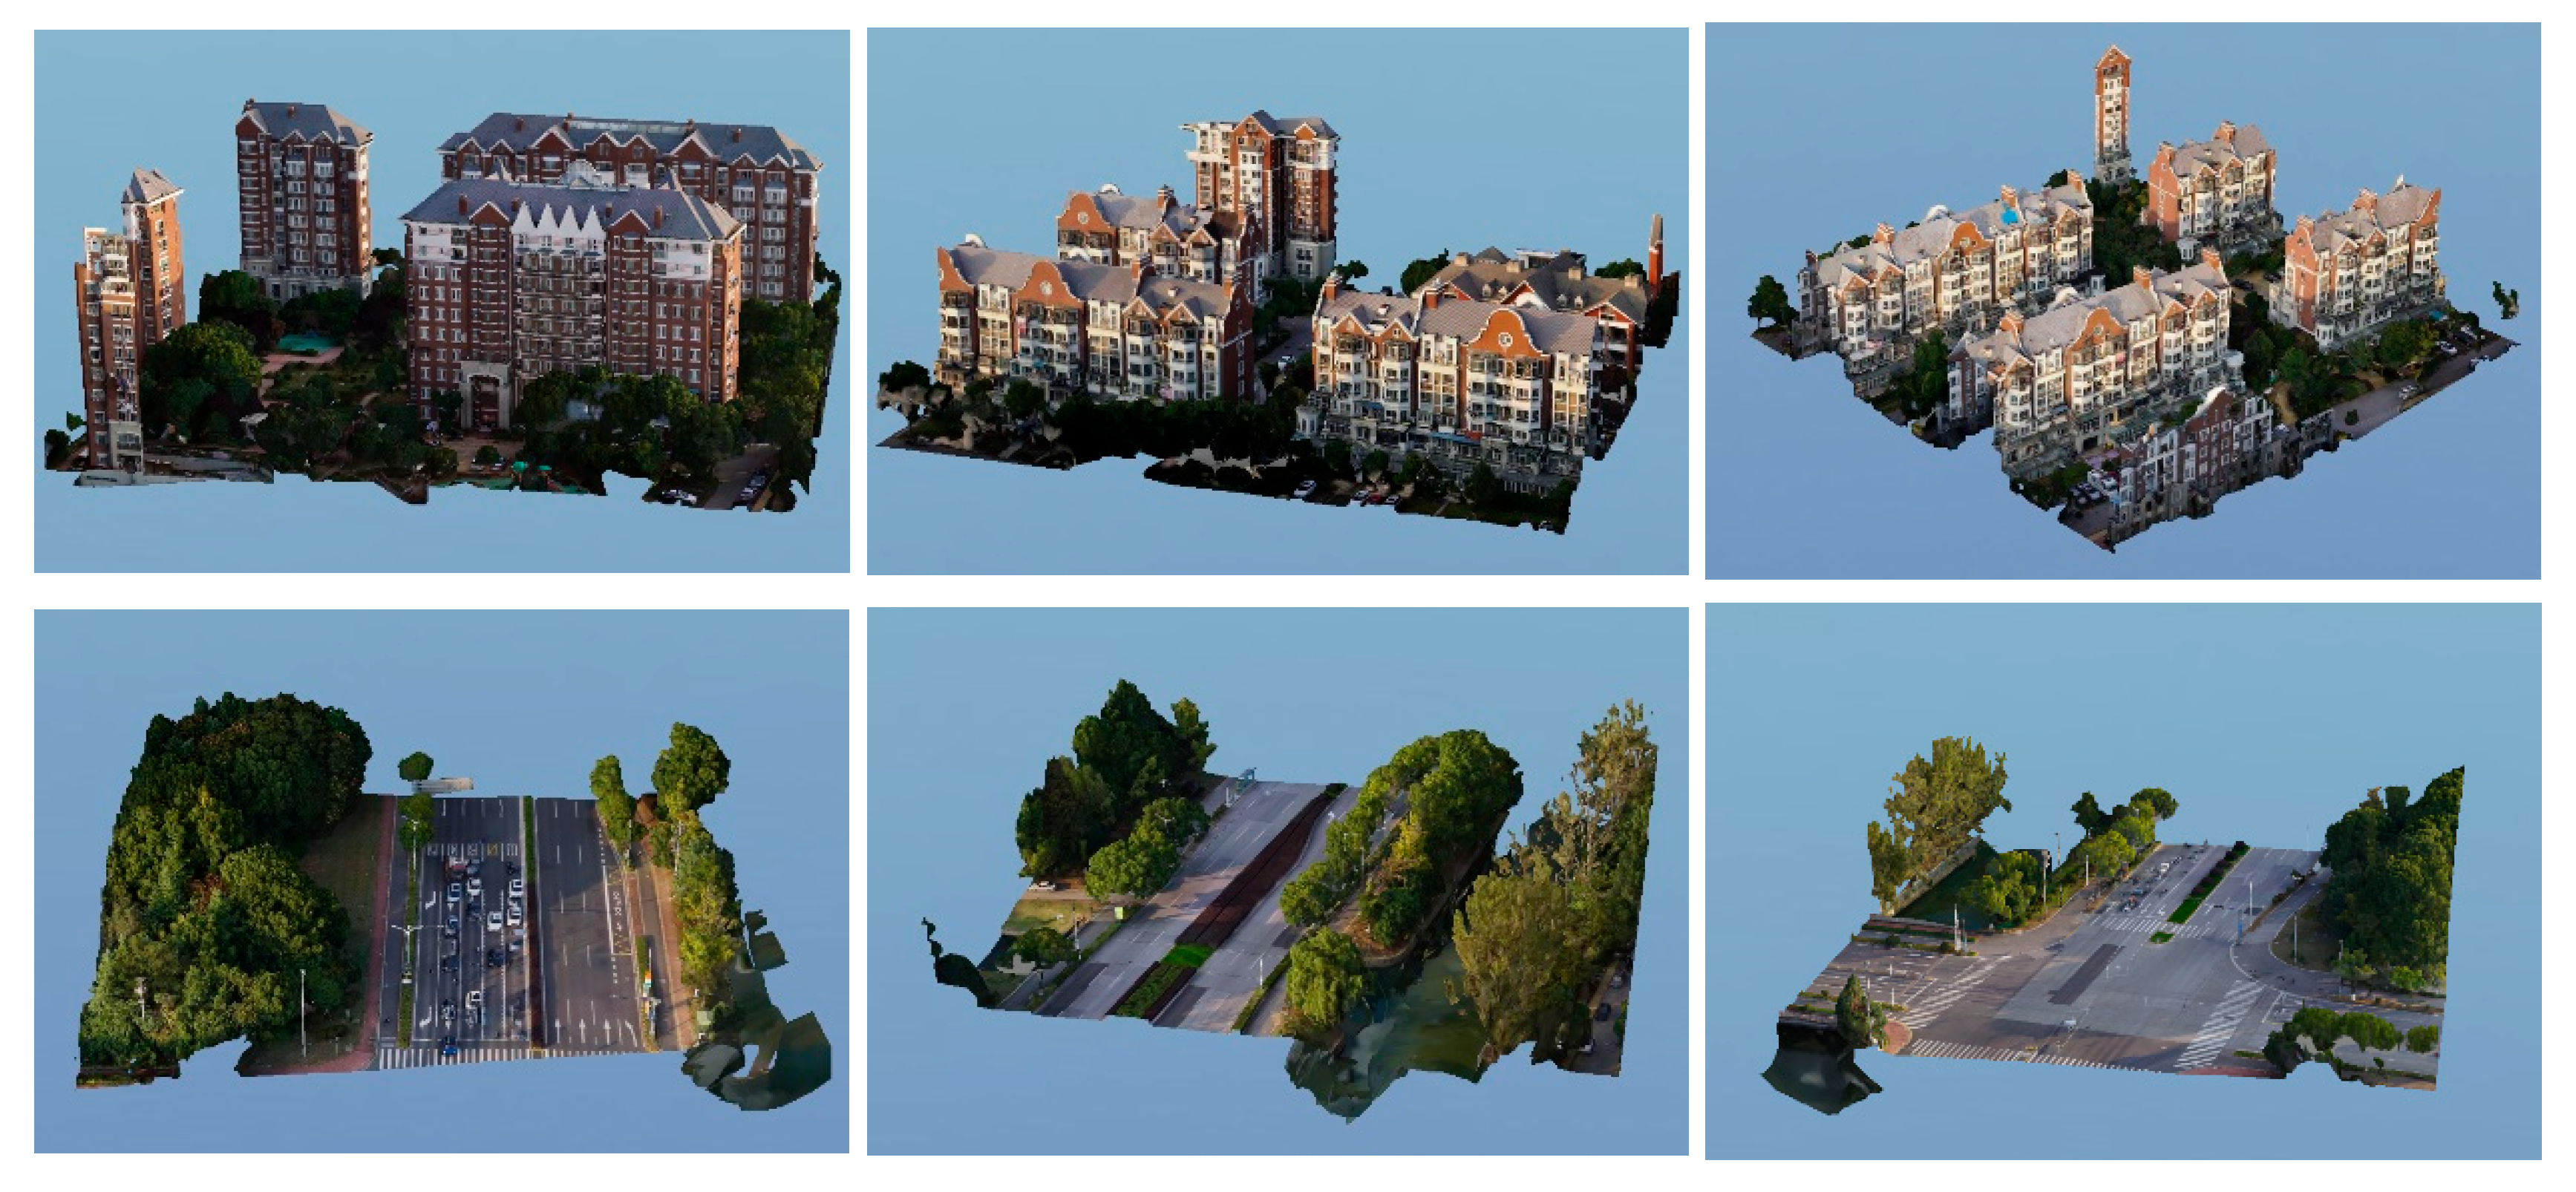
| 3D Model | Number of Points | Number of Meshes | Coordinate Range (x) | Coordinate Range (y) | Coordinate Range (z) |
|---|---|---|---|---|---|
| Model_01 | 2753 | 2803 | −100.15010834, 0.15001816 | −0.15010814, 100.15010834 | −6.11222792, 30.96369743 |
| Model_02 | 2060 | 2039 | −0.15034783, 110.7681130 | −243.5473909, −143.3426959 | −4.61764622, 29.22712517 |
| Model_03 | 2482 | 2397 | −100.15010834, 0.15001816 | −100.15010834, 0.15010814 | −4.81751442, 27.58547592 |
| Model_04 | 5035 | 7964 | −310.65600732, −209.84999084 | 199.84999084, 281.8805542 | −21.88563919, 16.29739952 |
| Model_05 | 4827 | 5458 | −150.15011597, −49.44667969 | −0.15010813, 100.6561439 | −19.09381104, 21.78419495 |
| Model_06 | 2192 | 2313 | −200.5692138, −99.9826490 | 99.65783235, 200.15011597 | −16.38249207, 18.72704315 |
| 3D Models | Evaluation Parameters | ||
|---|---|---|---|
| HD | RMSE | PSNR | |
| Model_01 | 0.00899423 | 0.003446 | 109.02778 |
| Model_02 | 0.00899958 | 0.002434 | 97.57949 |
| Model_03 | 0.00899835 | 0.002837 | 90.85347 |
| Model_04 | 0.00899777 | 0.003218 | 95.85264 |
| Model_05 | 0.00900007 | 0.003368 | 85.73576 |
| Model_06 | 0.00899944 | 0.003376 | 85.57139 |
| mean value | 0.00899824 | 0.003113 | 94.10342 |
| Attack Type | Attack Intensity | Extracted Watermark | Evaluation Parameters | |
|---|---|---|---|---|
| NC | BER | |||
| Translation | Translate 60 m along the X-axis |  | 1.000 | 0.000% |
| Translate 60 m along the Y-axis |  | 1.000 | 0.000% | |
| Translate 60 m along the Z-axis |  | 1.000 | 0.000% | |
| Rotation | Rotate 45° around the X-axis |  | 1.000 | 0.000% |
| Rotate 45° around the Y-axis |  | 1.000 | 0.000% | |
| Rotate 45° around the Z-axis |  | 1.000 | 0.000% | |
| Attack Type | Crop Ratio | Extracted Watermark | Evaluation Parameters | |
|---|---|---|---|---|
| NC | BER | |||
| Cropping | 15% |  | 0.996 | 0.488% |
| 25% |  | 0.965 | 4.883% | |
| 40% |  | 0.926 | 10.645% | |
| Attack Type | Simplify Ratio | Extracted Watermark | Evaluation Parameters | |
|---|---|---|---|---|
| NC | BER | |||
| Simplify | 10% |  | 0.996 | 0.195% |
| 15% |  | 0.972 | 3.906% | |
| 20% |  | 0.907 | 13.086% | |
| Attack Type and Intensity | Wang [28] | Gong [29] | Qiu [23] | Lee [11] | Jiao [26] | Wang [30] | Our |
|---|---|---|---|---|---|---|---|
| Translate 60 m along the X-axis | 1.000 | 1.000 | 1.000 | 1.000 | 1.000 | 1.000 | 1.000 |
| Rotate 45° around the X-axis | 1.000 | 1.000 | 1.000 | 1.000 | 1.000 | 1.000 | 1.000 |
| Scaling 10% | 1.000 | 1.000 | 1.000 | 1.000 | 0.483 | 0.427 | 0.444 |
| Crop 15% | 0.970 | 0.987 | 0.388 | 0.925 | 0.981 | 0.989 | 0.994 |
| Simplify 10% | 0.511 | 0.493 | 0.961 | 0.834 | 0.674 | 0.528 | 0.996 |
| Recovered Models | t Takes the Values of 2 and 6 Sequentially | ||
|---|---|---|---|
| Maximum Change (Unit: m) | Minimum Change (Unit: m) | Average Change (Unit: m) | |
| Model_01 | 1.81659 × 10⁻¹¹ | 3.55271 × 10⁻¹⁵ | 3.69755 × 10⁻¹² |
| Model_02 | 4.79689 × 10⁻¹¹ | 1.42108 × 10⁻¹⁴ | 1.44995 × 10⁻¹¹ |
| Model_03 | 1.67708 × 10⁻¹¹ | 7.10542 × 10⁻¹⁵ | 5.05048 × 10⁻¹² |
| Model_04 | 1.68946 × 10⁻¹¹ | 1.42108 × 10⁻¹⁴ | 1.42108 × 10⁻¹² |
| Model_05 | 2.51867 × 10⁻¹¹ | 8.88178 × 10⁻¹⁶ | 6.84313 × 10⁻¹² |
| Model_06 | 1.32921 × 10⁻¹¹ | 7.10542 × 10⁻¹⁵ | 3.42056 × 10⁻¹² |
| Numerical mean | 2.30465 × 10⁻¹¹ | 5.04779 × 10⁻¹⁵ | 5.82205 × 10⁻¹² |
| 3D Model | t | Maximum Change (Unit: m) | Minimum Change (Unit: m) | Average Change (Unit: m) |
|---|---|---|---|---|
| Model_01 | 2 | 8.99975 × 10⁻⁷ | 2.21011 × 10⁻¹¹ | 3.88603 × 10⁻⁷ |
| 7 | 8.99418 × 10⁻³ | 1.54276 × 10⁻⁷ | 3.88174 × 10⁻³ | |
| Model_02 | 2 | 8.99973 × 10⁻⁷ | 2.43159 × 10⁻¹¹ | 3.85782 × 10⁻⁷ |
| 7 | 8.99940 × 10⁻³ | 2.69523 × 10⁻⁸ | 3.86710 × 10⁻³ | |
| Model_03 | 2 | 8.99966 × 10⁻⁷ | 2.22341 × 10⁻¹¹ | 3.85321 × 10⁻⁷ |
| 7 | 8.99833 × 10⁻³ | 1.02956 × 10⁻⁶ | 3.86065 × 10⁻³ | |
| Model_04 | 2 | 8.99739 × 10⁻⁷ | 3.79203 × 10⁻¹² | 3.87015 × 10⁻⁷ |
| 7 | 8.99773 × 10⁻³ | 2.04559 × 10⁻⁷ | 3.88255 × 10⁻³ | |
| Model_05 | 2 | 8.99671 × 10⁻⁷ | 6.46154 × 10⁻¹² | 3.90780 × 10⁻⁷ |
| 7 | 8.99998 × 10⁻³ | 8.62768 × 10⁻⁷ | 3.89817 × 10⁻³ | |
| Model_06 | 2 | 8.99590 × 10⁻⁷ | 1.91879 × 10⁻¹¹ | 3.92975 × 10⁻⁷ |
| 7 | 8.99941 × 10⁻³ | 2.53038 × 10⁻⁷ | 3.84723 × 10⁻³ |
| 3D Model | Number of Points | Number of Meshes | Coordinate Range (x) | Coordinate Range (y) | Coordinate Range (z) |
|---|---|---|---|---|---|
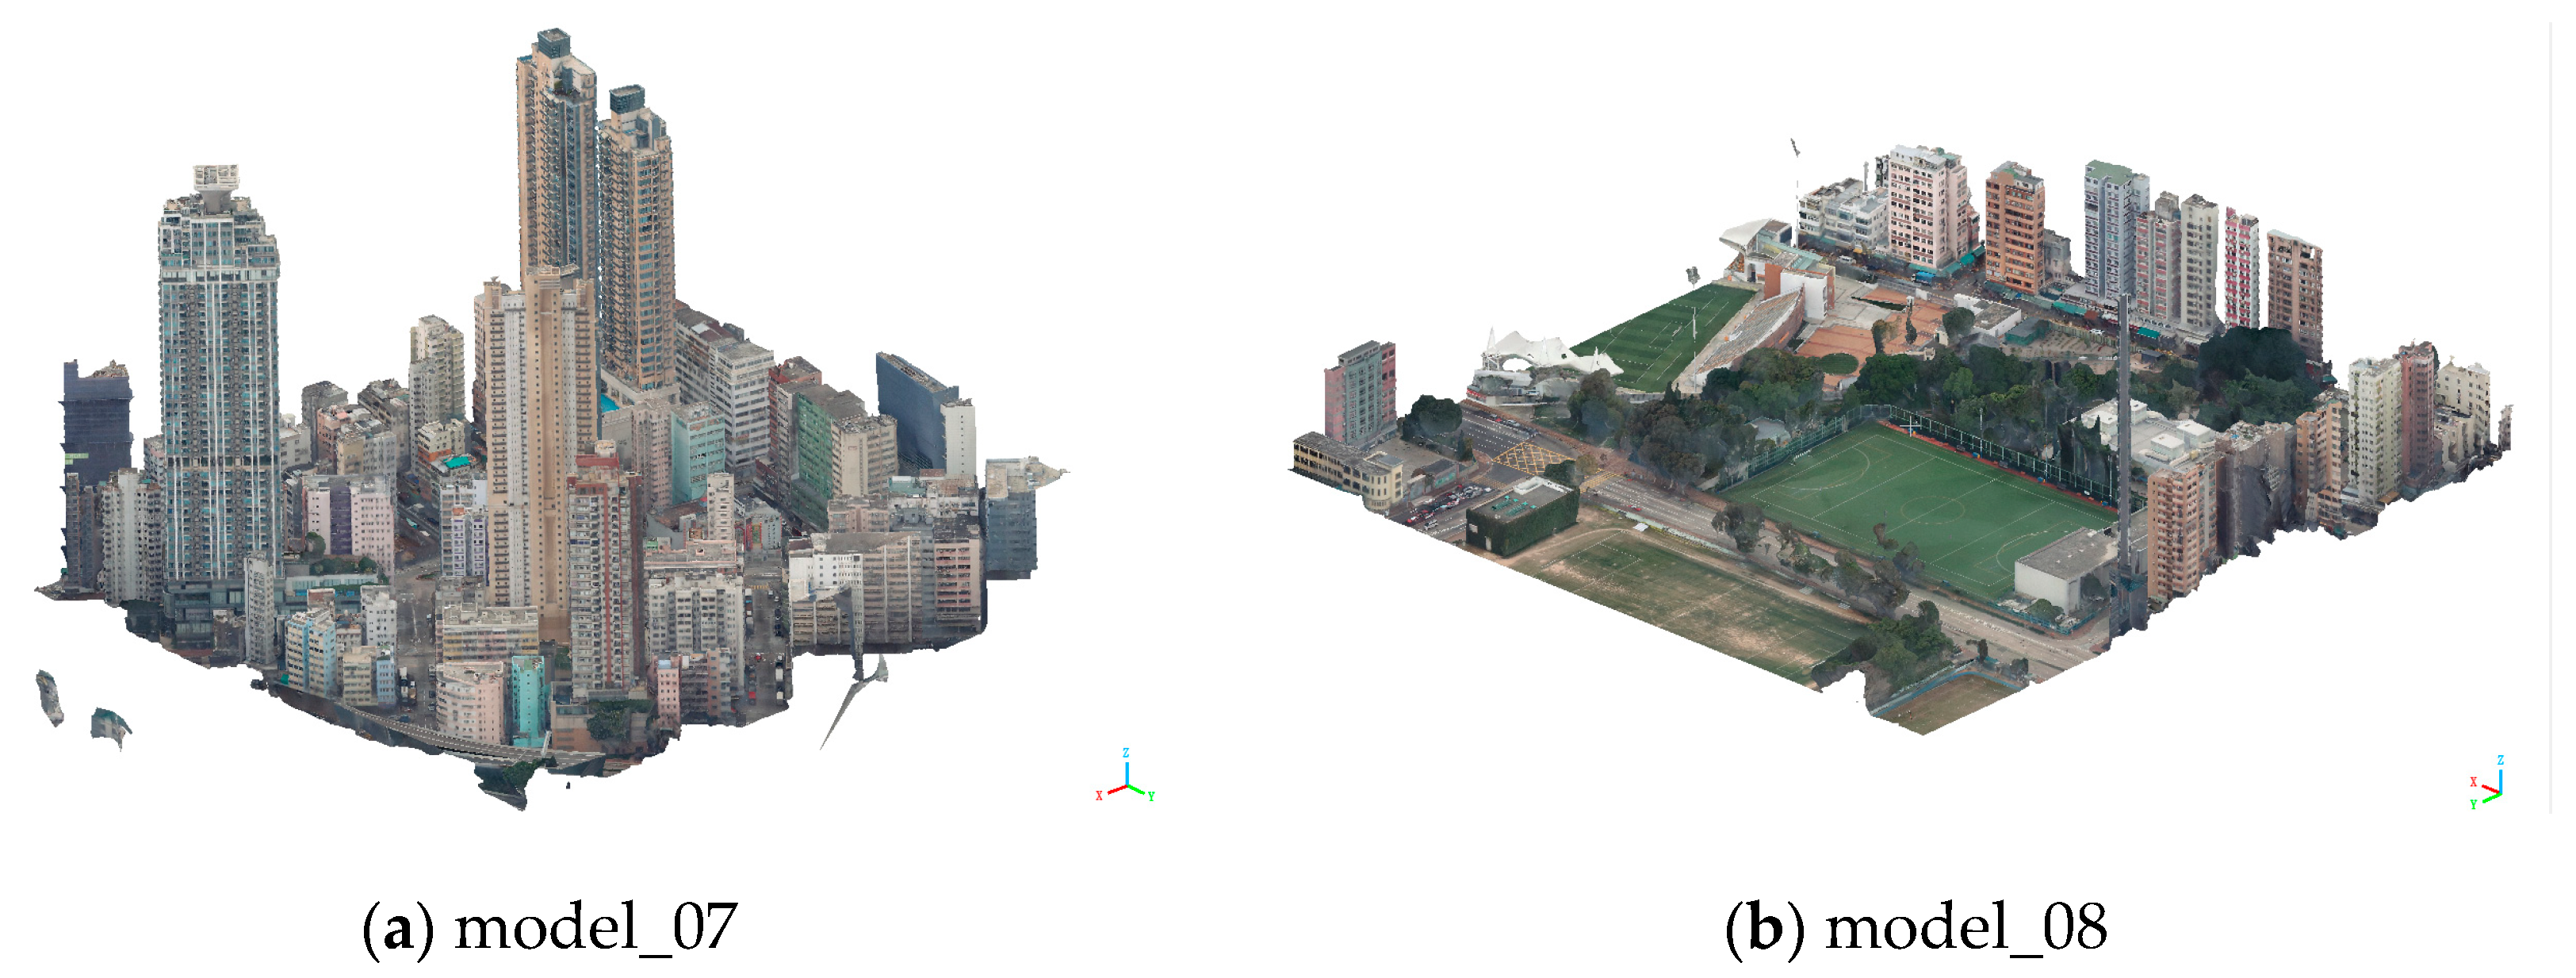
| Model_07 | 672,505 | 1,338,287 | −949.884, −694.049 | −705.810, −449.974 | −84.8697, 179.869 |
| Model_08 | 245,551 | 485,084 | −209.864, 45.9749 | −192.188, 63.6513 | −85.8668, 118.284 |
| Attack Type and Intensity | Model_07 | Model_08 |
|---|---|---|
| Translate 60 m along the X-axis | 1.000 | 1.000 |
| Rotate 45° around the X-axis | 1.000 | 1.000 |
| Scaling 10% | 0.463 | 0.452 |
| Crop 15% | 0.996 | 0.995 |
| Simplify 10% | 0.997 | 0.997 |
| Recovered Models | t Takes the Values of 2 and 6 Sequentially | ||
|---|---|---|---|
| Maximum Change (Unit: m) | Minimum Change (Unit: m) | Average Change (Unit: m) | |
| Model_07 | 1.46744 × 10⁻¹¹ | 5.27363 × 10⁻¹⁵ | 1.68283 × 10⁻¹² |
| Model_08 | 1.57318 × 10⁻¹¹ | 7.83217 × 10⁻¹⁵ | 1.47367 × 10⁻¹² |
| 3D Model | t | Maximum Change (Unit: m) | Minimum Change (Unit: m) | Average Change (Unit: m) |
|---|---|---|---|---|
| Model_07 | 2 | 8.99917 × 10⁻⁷ | 1.91742 × 10⁻¹¹ | 3.74832 × 10⁻⁷ |
| 7 | 8.99832 × 10⁻³ | 1.46284 × 10⁻⁷ | 3.74208 × 10⁻³ | |
| Model_08 | 2 | 8.99961 × 10⁻⁷ | 2.35673 × 10⁻¹¹ | 3.72339 × 10⁻⁷ |
| 7 | 8.99938 × 10⁻³ | 2.45806 × 10⁻⁸ | 3.73345 × 10⁻³ |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Qu, R.; Zhang, L.; Hou, Z.; Zhang, M. Precision Controllable Reversible Watermarking Algorithm for Oblique Photography 3D Models. Sensors 2026, 26, 243. https://doi.org/10.3390/s26010243
Qu R, Zhang L, Hou Z, Zhang M. Precision Controllable Reversible Watermarking Algorithm for Oblique Photography 3D Models. Sensors. 2026; 26(1):243. https://doi.org/10.3390/s26010243
Chicago/Turabian StyleQu, Ruitao, Liming Zhang, Zhaoyang Hou, and Mingwang Zhang. 2026. "Precision Controllable Reversible Watermarking Algorithm for Oblique Photography 3D Models" Sensors 26, no. 1: 243. https://doi.org/10.3390/s26010243
APA StyleQu, R., Zhang, L., Hou, Z., & Zhang, M. (2026). Precision Controllable Reversible Watermarking Algorithm for Oblique Photography 3D Models. Sensors, 26(1), 243. https://doi.org/10.3390/s26010243