


Autonomous Drilling and the Idea of Next-Generation Deep Mineral Exploration


 , , , ,
Abstract
1. Introduction
2. Drilling Systems and Peripherals
- Basic automation: In this stage, all parts of the processes are triggered by humans, governed by very simple rules, with no integration with other systems.
- Robotic process automation (RPA): This involves more than one system, where parts of the process may still be triggered by humans, while mundane tasks are handled by interoperable processes. Although the rules remain simple, this allows for higher volumes of work to be processed, though it is still limited to structured data and operates at an enterprise level.
- Enhanced process automation: Here, human input is augmented by basic analytics and decision support. Unstructured data comes into play through intelligent document processing and optical character recognition, with integration extending to basic web applications, such as company search engines.
- Algorithmic automation: This stage enables complex data-based decision-making, where humans select the best option informed by predictive and prescriptive analytics. It may involve rudimentary machine learning that suggests optimal decisions while incorporating unstructured and big data, thereby increasing the complexity of algorithms. Advanced integration with the internet of things (IoT) is also possible.
- Artificial intelligence: At this level, cognitive technology mimics human decision-making capabilities, offering end-to-end autonomy that includes reasoning and hypothesizing. This stage involves deep learning linked to neural networks, as well as speech recognition and generation, augmented reality, and virtual reality.
3. Navigation of Autonomous Machines in Uncharted Areas
4. Next-Generation Deep Mineral Exploration Drilling Systems and Autonomous Drill Planning and Execution from Onboard Sensing of Rock Face Characteristics
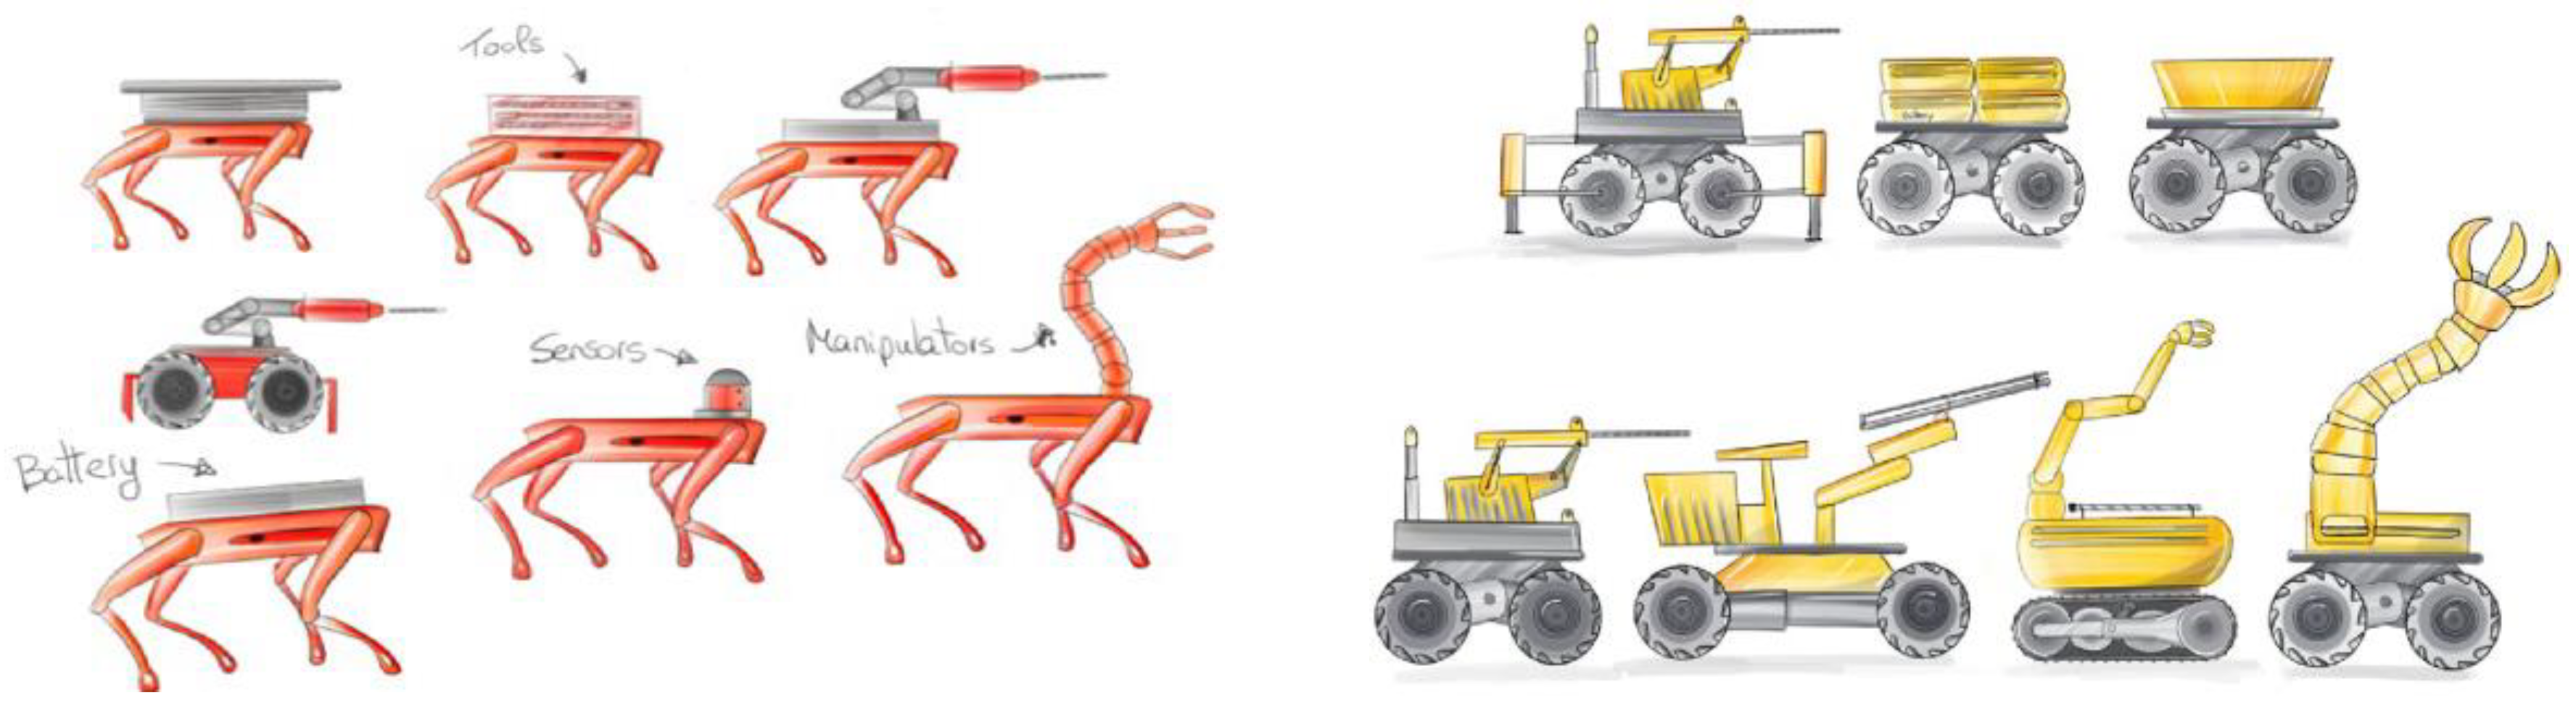
4.1. Modular System for the Deployment of Exploration Drilling Rigs and Measurement Systems, Leveraging Existing Robotic Solutions
- Traversal success rate: The percentage of tunnel sections completed without human intervention.
- Exploration coverage rate: The area mapped per unit of time (e.g., square meters per minute).
- Energy consumption: The energy required to complete specific tasks.
- Reconfiguration time: The average time required to switch between modules or tools.
- Research into existing robotic drilling technologies and modular systems.
- CAD design.
- Prototyping and testing conducted in a laboratory environment.
- Integration of hardware and software for the prototyped components into existing robotic solutions.
- (1)
- Traversability of the mine.
- (2)
- Distribution of loads and transportation of electrical and drilling mediums.
- (3)
- Physical collaboration for precise exploration drilling.
4.2. Autonomous Drill Planning and Execution Systems That Utilize the Onboard Sensing of Rock Face Characteristics
- Conduct theoretical research to understand the principles of onboard sensing and its application in autonomous drilling.
- Investigate and adapt existing sensor technologies and data processing algorithms for the specific use cases outlined in the PERSEPHONE project.
- Establish seamless communication and coordination between robotic systems and tools, thereby enhancing their ability to perform complex maneuvers with precision and efficiency.
4.3. PERSEPHONE Autonomous Drill Planning and Execution Approach
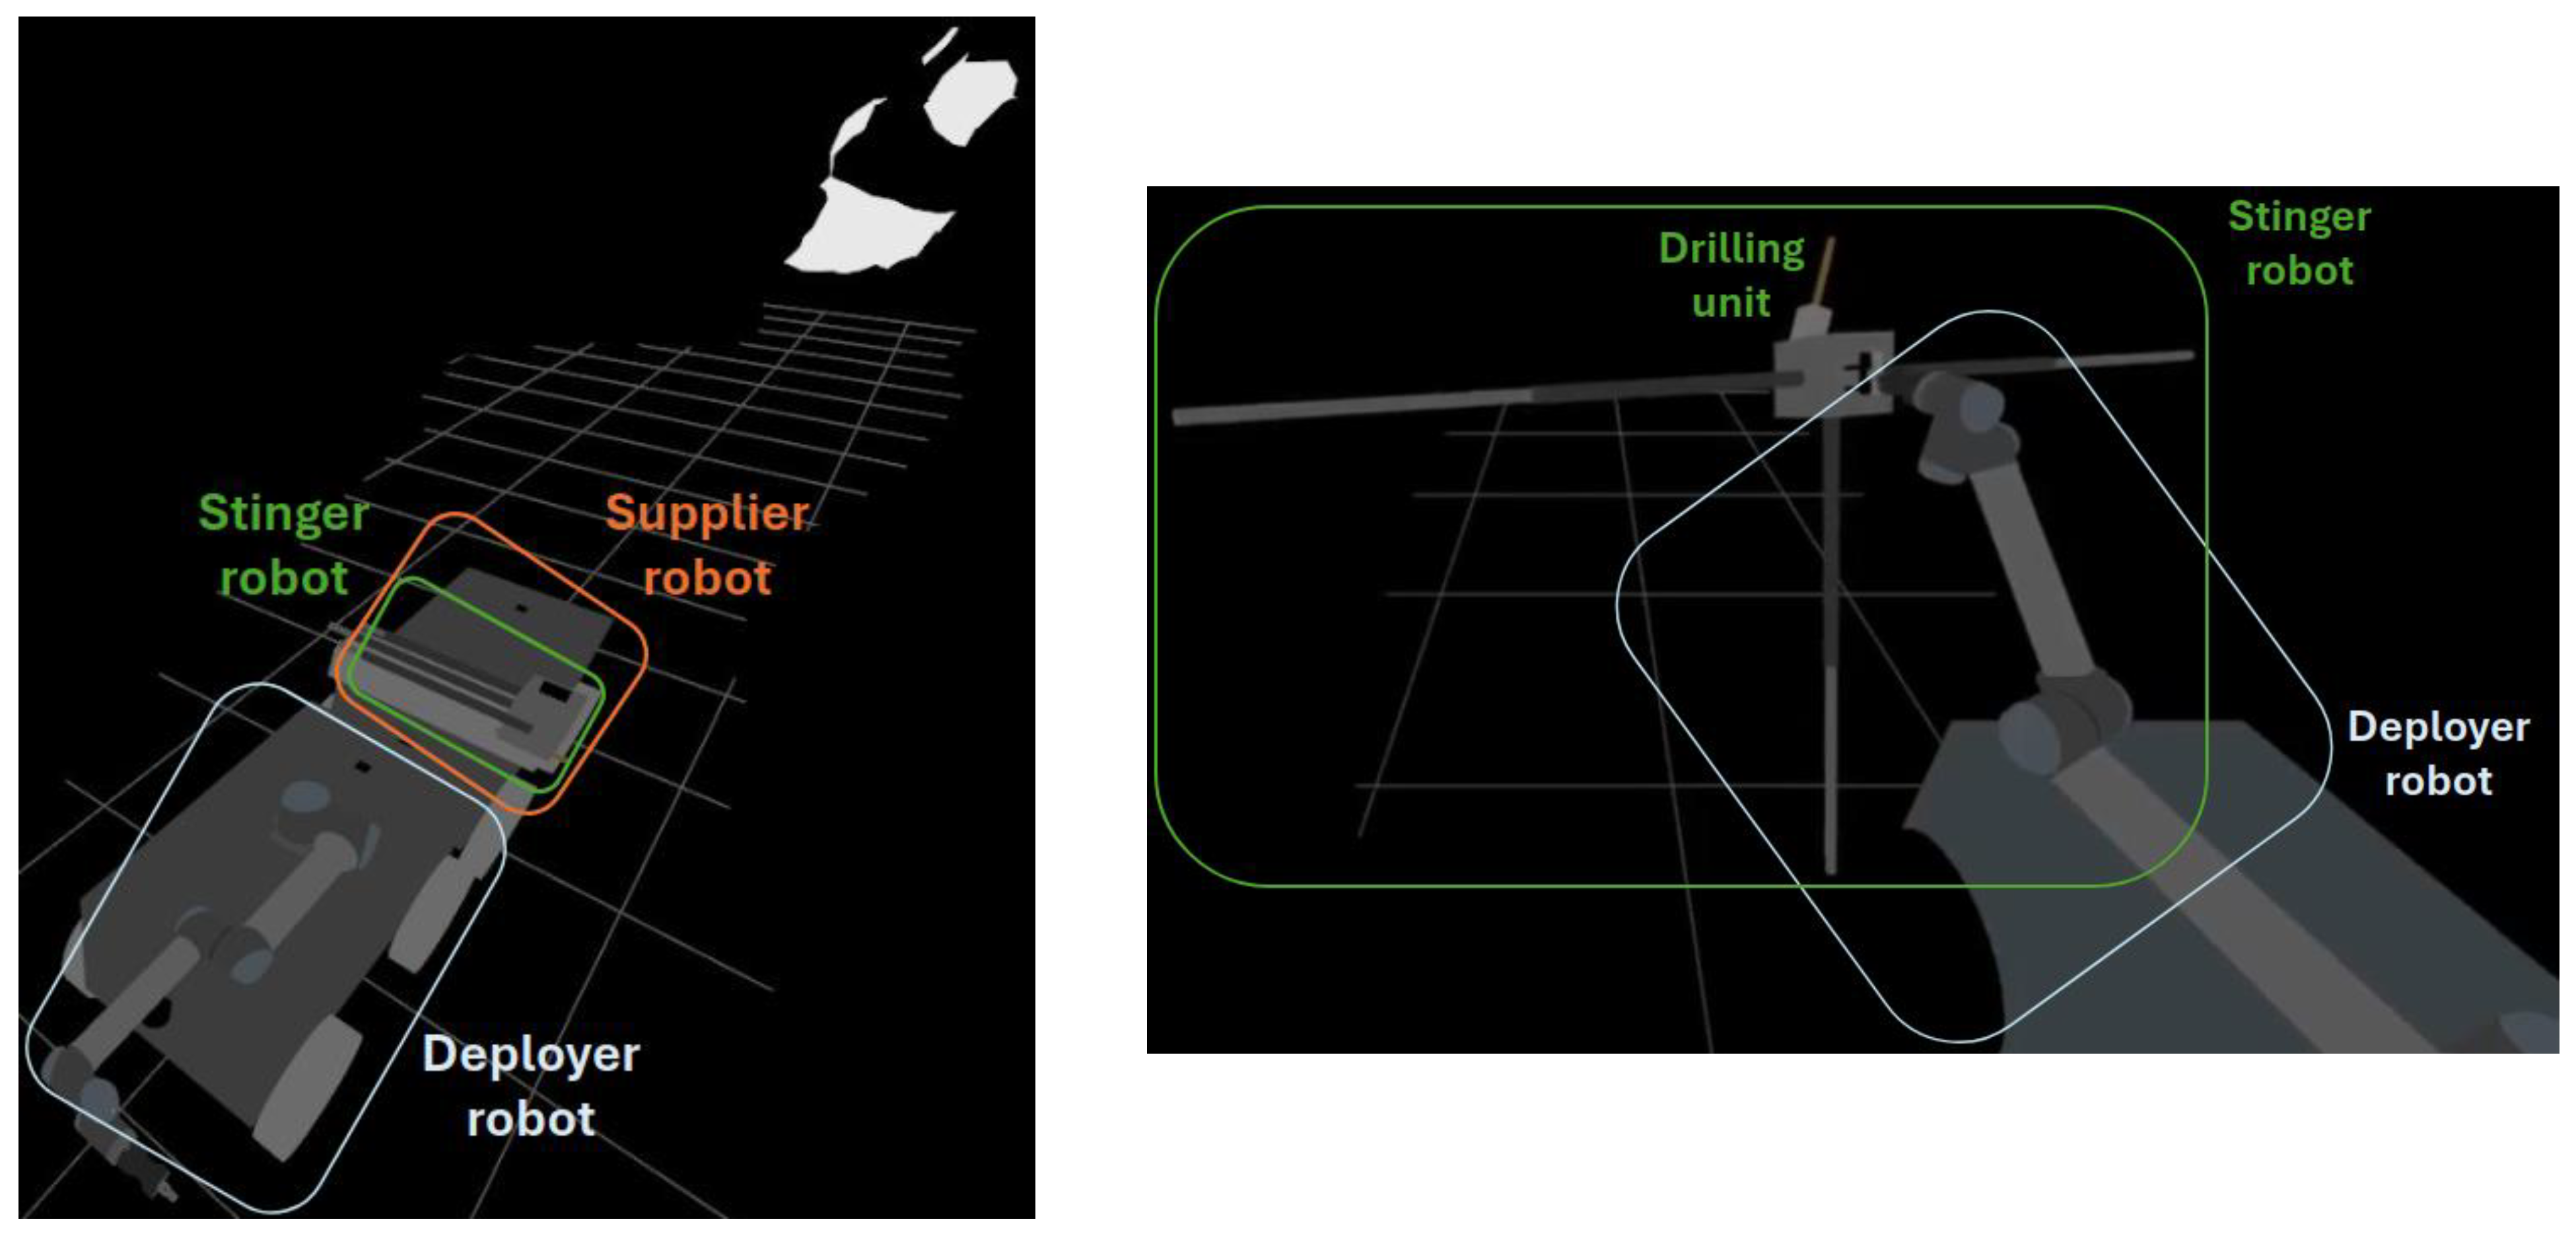
- Deployer robot: A ground vehicle equipped with a six-DoF industrial manipulator and an array of sensors (e.g., LiDAR, cameras, IMU, LIBS). Its roles include 3D environment scanning, deployment site analysis, and manipulation tasks such as placing and servicing the drilling tool.
- Supplier robot: A logistics agent with a high payload capacity, designed to transport essential resources like power units, drilling consumables, and water, or even the stinger robot. It acts as a mobile depot that dynamically supports the drilling operation.
- Stinger robot: A compact, custom-built drilling agent with a deployable anchoring system and an integrated drilling unit. It is capable of self-anchoring, performing multi-hole drilling operations, and adjusting the drilling parameters based on local sensor feedback.
- Environment mapping: The deployer robot scans the local geometry to create a 3D map of the area.
- Deployment site selection: Using its onboard perception, the deployer analyzes the terrain to identify suitable locations for anchoring the stinger robot.
- Stinger robot deployment: The deployer retrieves the stinger robot (either from itself or from the supplier), navigates to the chosen site, and performs precise pick-and-place operations for deployment. Once the stinger robot is successfully placed, the deployer communicates the completion to it, enabling further actions.
- Anchoring and resource supply: After receiving clearance from the deployer, the stinger robot begins deploying its anchoring system and confirms stability using its onboard sensors. The deployer or supplier supplies power, water, and drilling tools as needed, based on requests from the stinger robot.
- Drilling execution: The stinger robot conducts adaptive drilling, utilizing local sensing to adjust to material properties or disturbances. It can reposition its drilling head to create multiple holes per deployment.
- Repositioning (if required): If additional drilling is needed beyond the robot’s reach or if there is a failure in any other phase of the mission, the stinger robot communicates the issue to the deployer. The deployer will then retrieve and relocate the stinger robot to a new site, repeating the deployment and drilling cycle.
- Mission completion: After the drilling plan is completed, the fleet consolidates, stores the stinger robot, and awaits further tasks or extraction.
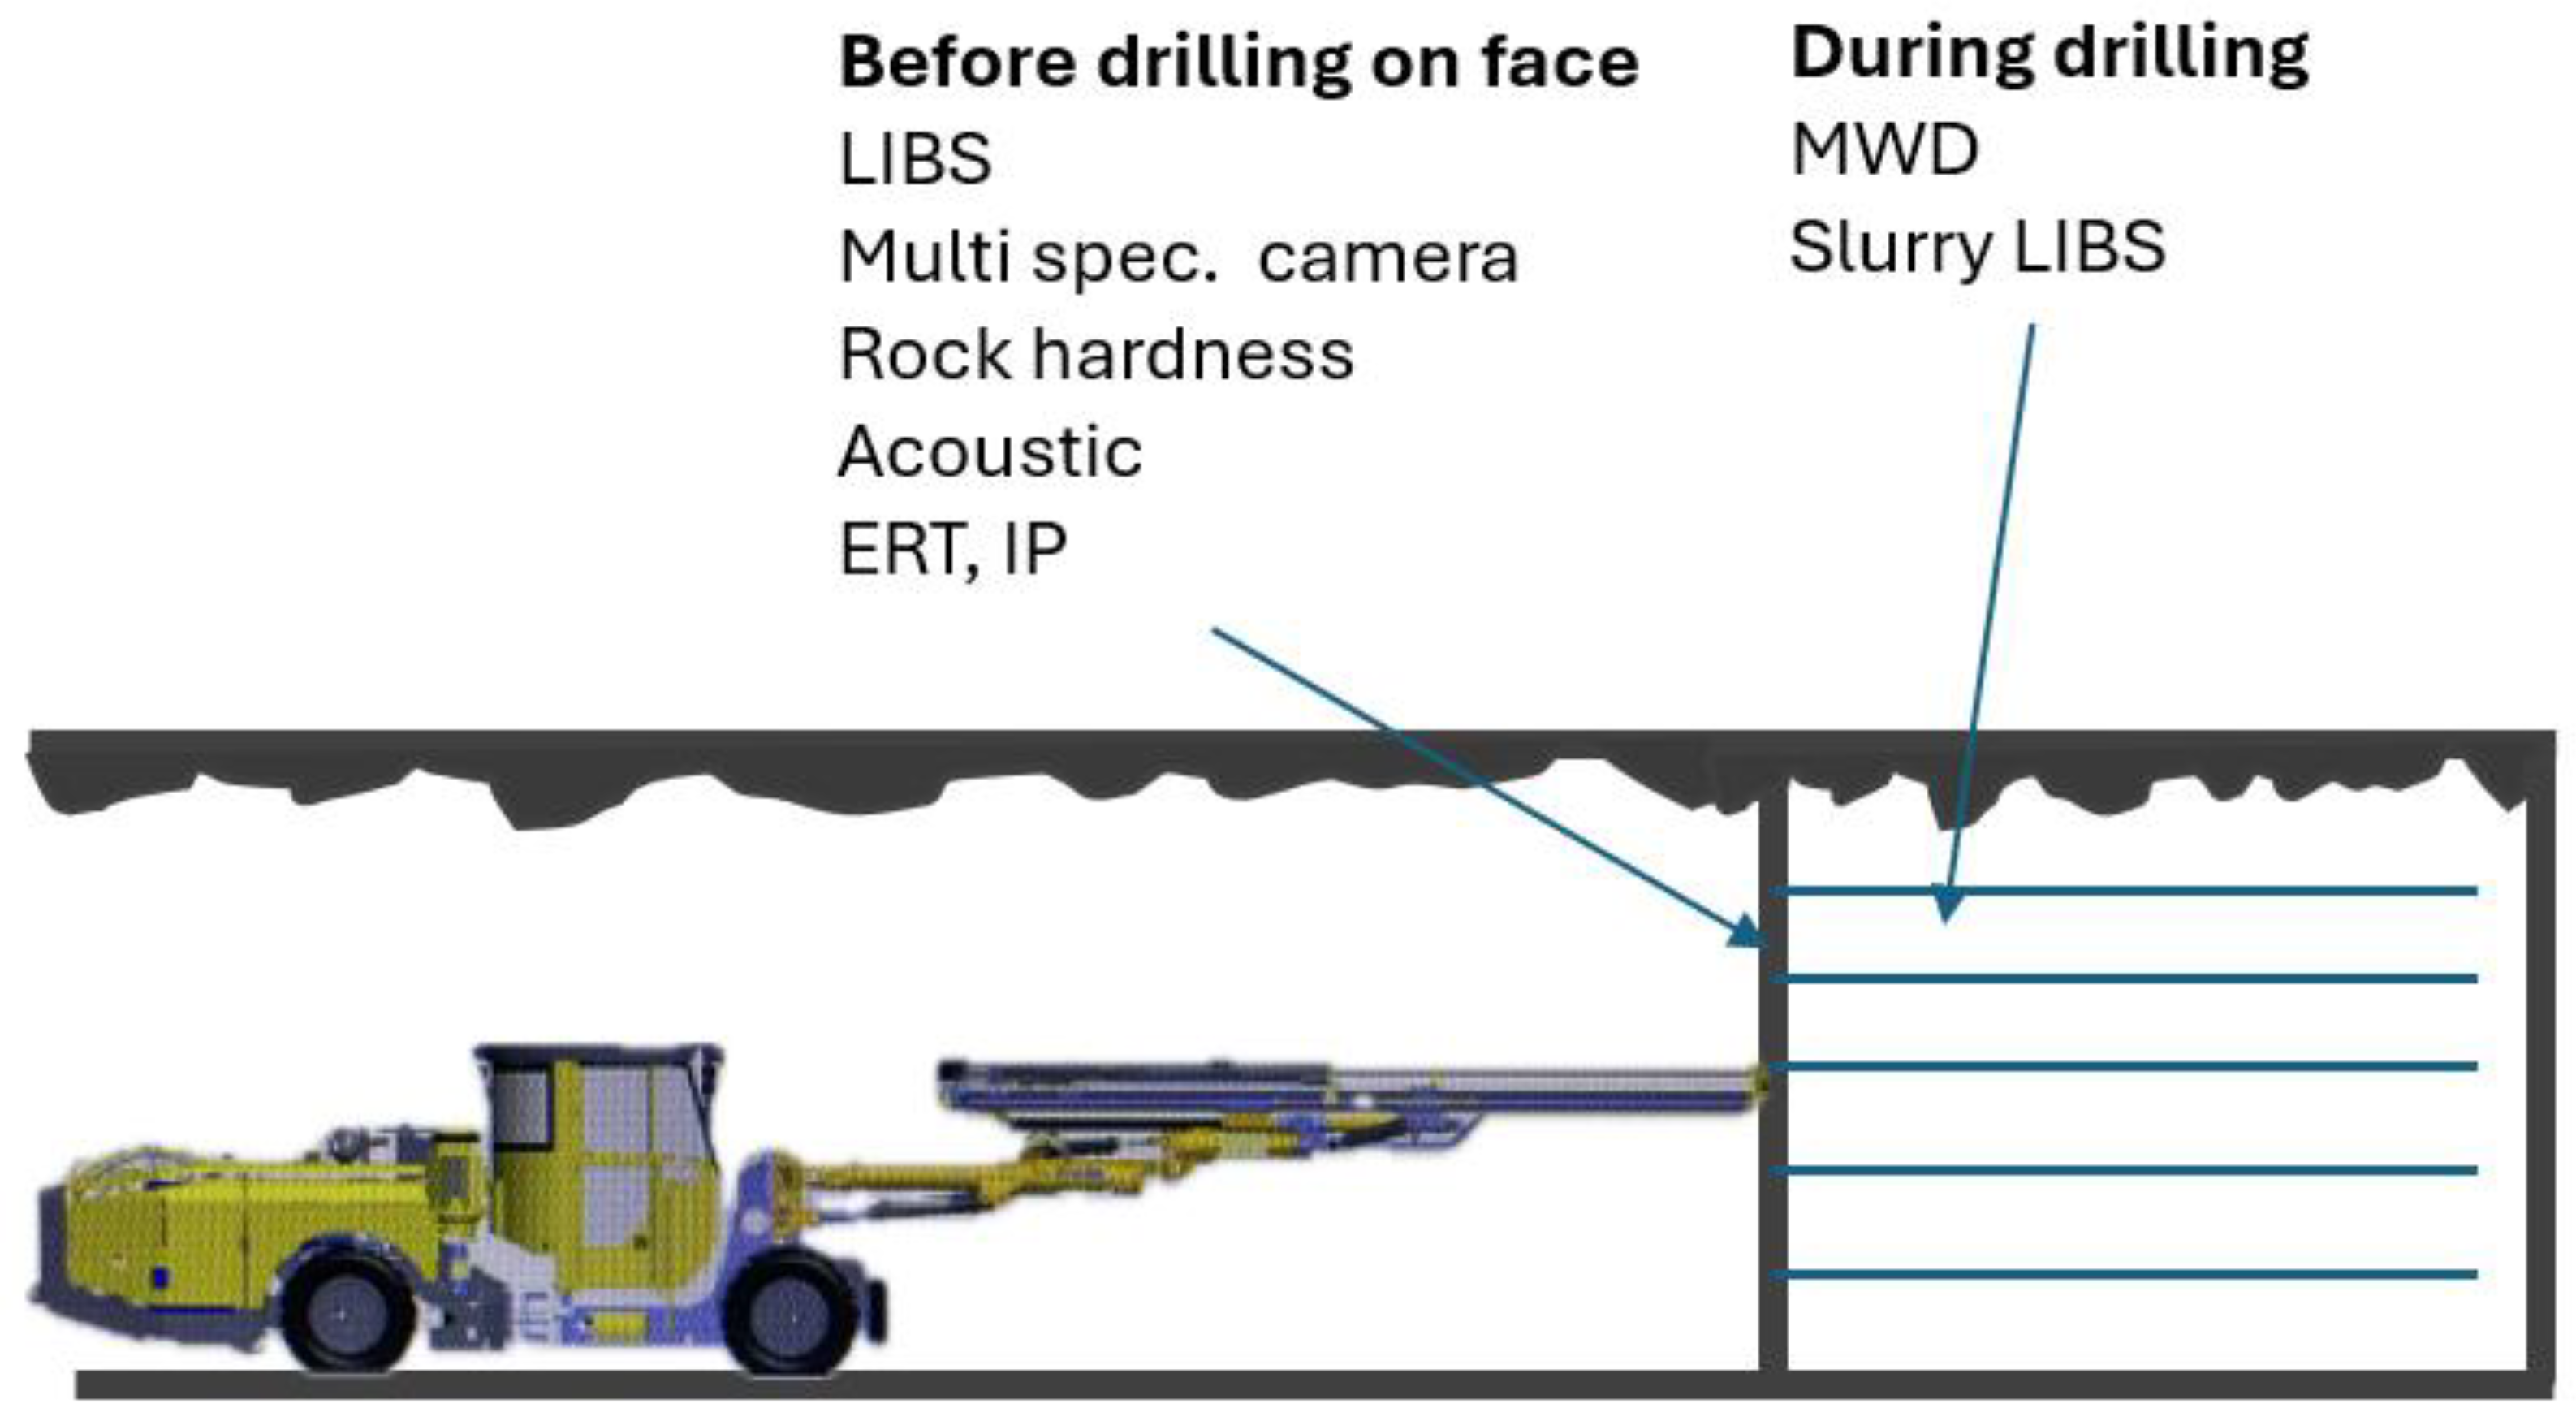
5. Real-Time Rock Characterization and Detection of Rock Mechanical and Geophysical Properties Supported by Advanced Online Analytics Systems for the Planning and Characterization of Near-Mine Exploratory Drilling
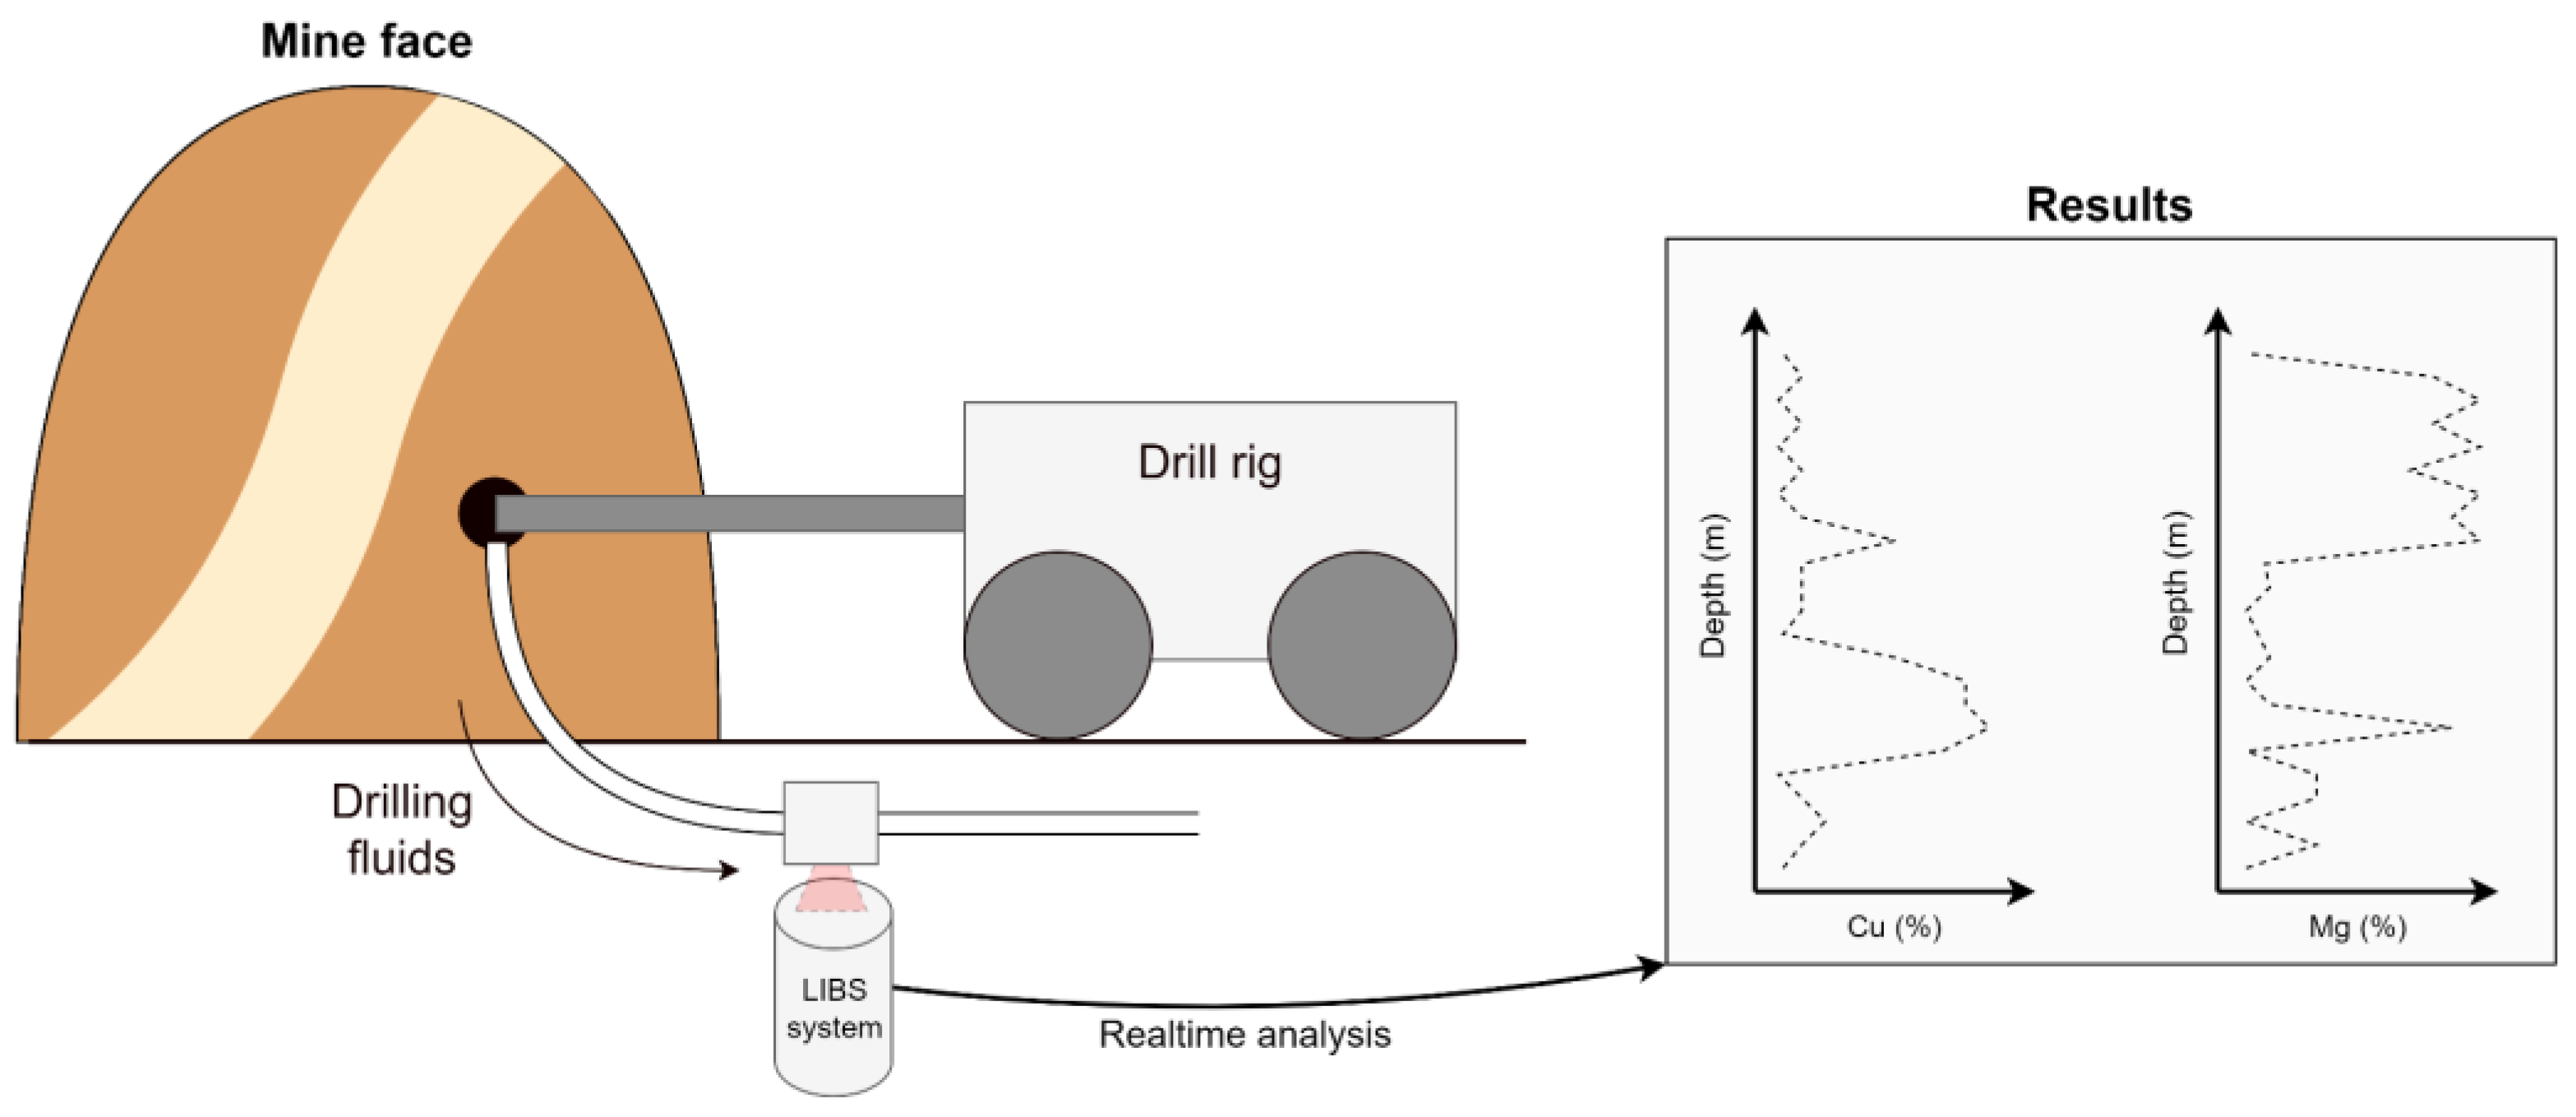
5.1. LIBS Slurry Analyzer
5.2. LIBS Mine-Face Scanning
6. Conclusions
- Energy efficiency: The ability to adjust the drilling patterns dynamically—based on real-time sensing of rock properties—is expected to reduce unnecessary boreholes and associated energy consumption during drilling operations.
- Reduction in explosive use: By aligning charge placement with localized geomechanical feedback, the system can help optimize fragmentation and limit overbreak, leading to a more efficient use of explosives.
- Minimized human exposure: Through the deployment of autonomous systems for drilling and preconditioning in difficult-to-access or hazardous areas, the need for direct human intervention is expected to be significantly reduced, enhancing overall occupational safety.
- Lower emissions and ventilation demand: The integration of electric-powered autonomous platforms in place of conventional diesel-driven equipment may reduce underground emissions and help optimize ventilation strategies, particularly in deep or poorly ventilated areas.
- Modular reusability and lifecycle extension: The modular architecture of the robotic systems allows for targeted maintenance and upgrades, thereby reducing waste and increasing the longevity of critical hardware components.
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Song, D.; Liu, H.; Zhang, Q.; Wang, Z.; Xu, J. Application of Integrated Drilling and Stamping Technology in Gas Extraction through Layer Drilling. Energy Explor. Exploit. 2022, 40, 1685–1704. [Google Scholar] [CrossRef] [Scilit]
- Abreu, R.; Knox, G. The Influence of Drilling on the Performance of a Yielding Self-Drilling Rockbolt. In Proceedings of the Caving 2022: Fifth International Conference on Block and Sublevel Caving, Adelaide, Australia, 30 August–1 September 2022; Australian Centre for Geomechanics: Perth, Australia, 2022; pp. 165–176. [Google Scholar]
- Ling, X.; Zhang, T.; Chen, X.; Gao, Z. Hydraulic Rock Drill Fault Classification Using X−Vectors. Mathematics 2023, 11, 1724. [Google Scholar] [CrossRef] [Scilit]
- Cheluszka, P. Numerical Studies of the Dynamics of the Roadheader Equipped with an Automatic Control System during Cutting of Rocks with Different Mechanical Properties. Energies 2021, 14, 7353. [Google Scholar] [CrossRef] [Scilit]
- Cheng, X.; Liu, C.; Yu, Q. A Novel Vision-Guided Strategy for Accurately Delivering the Drill Pipe of the Horizontal Directional Drilling Rigs. Proc. SPIE 2023, 12720, 12540. [Google Scholar] [CrossRef] [Scilit]
- Lu, J.; Zhao, H.; Liang, G.; Li, B.; Pan, J. Algorithm for Automatic Rod Feeding and Positioning Error Compensation for Underground Drilling Robots in Coal Mines. Sensors 2023, 23, 7530. [Google Scholar] [CrossRef] [Scilit]
- Ding, X.; Liu, Y. Applying Coordinate Fixed Denavit–Hartenberg Method to Solve the Workspace of Drilling Robot Arm. Int. J. Adv. Robot. Syst. 2018, 15, 1729881418793283. [Google Scholar] [CrossRef] [Scilit]
- Zeng, Z.; Dang, X.; Li, Y.; Huang, Y.; Liang, X. A mmWave Radar SLAM Method in Subterranean Tunnel for Low Visibility and Degradation. IEEE Robot. Autom. Lett. 2024, 9, 4281–4288. [Google Scholar] [CrossRef] [Scilit]
- Jacobson, A.; Zeng, F.; Smith, D.; Boswell, N.; Peynot, T.; Milford, M. What localizes beneath: A metric multisensor localization and mapping system for autonomous underground mining vehicles. J. Field Robot. 2021, 38, 5–27. [Google Scholar] [CrossRef] [Scilit]
- Luo, S.; Wei, M.; Chen, Z. Research on Obstacle Avoidance for Automatic Drill Rods Replacement Robot in Coal Mines. Preprint 2024. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Zhao, J.; Liu, T.; Ma, R.; Han, Z. Drilling Path Planning of Rock-Drilling Jumbo Using a Vehicle-Mounted 3D Scanner. Sustainability 2023, 15, 9737. [Google Scholar] [CrossRef] [Scilit]
- Bendemra, H.; Goodall, R.M.; Gao, Y. Force Sensing Drill Jig for Robotic Assisted Drilling. Ind. Robot 2018, 45, 135–142. [Google Scholar] [CrossRef] [Scilit]
- Gu, S.; Liu, Y.; Wang, H.; Zhang, T. A Walking Trajectory Tracking Control Based on Uncertainties Estimation for a Drilling Robot for Rockburst Prevention. Machines 2024, 12, 298. [Google Scholar] [CrossRef] [Scilit]
- You, Y.; Zhang, Y.; Gao, D.; Li, Y.; Wang, X. Tracking System for a Coal Mine Drilling Robot for Low-Illumination Environments. Appl. Sci. 2022, 13, 568. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.; Huang, Y.; Zhao, C.; Wang, M. Development of Comprehensive Acquisition Software for Measurement While Drilling Data Based on VUE Coal Mine. E3S Web Conf. 2023, 406, 04038. [Google Scholar] [CrossRef] [Scilit]
- El-Rabbany, A. Introduction to GPS: The Global Positioning System; Artech House: Boston, MA, USA, 2002. [Google Scholar]
- Hellmers, H.; Norrdine, A.; Blankenbach, J.; Eichhorn, A. An IMU/Magnetometer-Based Indoor Positioning System Using Kalman Filtering. In Proceedings of the International Conference on Indoor Positioning and Indoor Navigation, Montbeliard, France, 28–31 October 2013; pp. 1–9. [Google Scholar]
- Lin, X.; Yao, W.; Yan, T. A LiDAR SLAM Algorithm Considering Dynamic Extraction of Feature Points in Underground Coal Mine. Int. Arch. Photogramm. Remote Sens. Spat. Inf. Sci. 2024, XLVIII-4-2024, 659–664. [Google Scholar] [CrossRef] [Scilit]
- Ebadi, K.; Bernreiter, L.; Biggie, H.; Catt, G.; Chang, Y.; Chatterjee, A.; Denniston, C.E.; Deschênes, S.-P.; Harlow, K.; Khattak, S.; et al. Present and Future of SLAM in Extreme Environments: The DARPA SubT Challenge. IEEE Trans. Robot. 2024, 40, 936–959. [Google Scholar] [CrossRef] [Scilit]
- Chinavaenzwa, M.; Munsamy, M.; Pretorius, J.H. Evaluation of a collision avoidance system at an underground mine. In Proceedings of the 2023 IEEE International Conference on Industrial Engineering and Engineering Management (IEEM), Singapore, 18–21 December 2023; pp. 1593–1597. [Google Scholar]
- Pan, Y.; Huo, F.; Wang, Z.; Zhai, S.; Geng, Z. A millimeter-wave radar tunnel obstacle detection method based on invalid target filtering. Appl. Sci. 2023, 13, 6720. [Google Scholar] [CrossRef] [Scilit]
- Liu, W.; Yu, J.; Zhang, Q.; Wang, L. Research on the Drilling State Intelligent Sensing and Adaptive Optimization Control of the Fast Drilling Robot. J. Phys. Conf. Ser. 2024, 2902, 012045. [Google Scholar] [CrossRef] [Scilit]
- Schmuck, P.; Chli, M. CCM-SLAM: Robust and Efficient Centralized Collaborative Monocular Simultaneous Localization and Mapping for Robotic Teams. J. Field Robot. 2019, 36, 763–781. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Zhang, M.; Wang, B.; Chen, L. A Conceptual Scale Model of Mobile Drilling Robot. Assem. Autom. 2019, 39, 610–618. [Google Scholar] [CrossRef] [Scilit]
- Seguel, F.; Palacios-Jativa, P.; Azurdia-Meza, C.A.; Krommenacker, N.; Charpentier, P.; Soto, I. Underground Mine Positioning: A Review. IEEE Sens. J. 2022, 22, 4755–4771. [Google Scholar] [CrossRef] [Scilit]
- Cotrim, J.R.; Kleinschmidt, J.H. LoRaWAN Mesh Networks: A Review and Classification of Multihop Communication. Sensors 2020, 20, 4273. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Agha, A.; Otsu, K.; Morrell, B.; Fan, D.D.; Thakker, R.; Santamaria-Navarro, A.; Kim, S.-K.; Bouman, A.; Lei, X.; Edlund, J.; et al. Nebula: Quest for robotic autonomy in challenging environments; team costar at the darpa subterranean challenge. arXiv 2021, arXiv:2103.11470. [Google Scholar]
- Tranzatto, M.; Mascarich, F.; Bernreiter, L.; Godinho, C.; Camurri, M.; Khattak, S.; Dang, T.; Reijgwart, V.; Loeje, J.; Wisth, D.; et al. Cerberus: Autonomous legged and aerial robotic exploration in the tunnel and urban circuits of the darpa subterranean challenge. arXiv 2022, arXiv:2201.07067. [Google Scholar] [CrossRef] [Scilit]
- Bustos, N.; Villaescusa, E.; Onederra, I. Analysis of Drillhole Deviation During Drawbell Construction in Block Caving. In MassMin 2020: Proceedings of the 8th International Conference & Exhibition on Mass Mining; University of Chile: Santiago, Chile, 2020; pp. 883–896. [Google Scholar]
- Adebayo, B.; Akande, J.M. Effects of Blast-Hole Deviation on Drilling and Muck-Pile Loading Cost. Int. J. Sci. Res. Innov. Technol. 2015, 2, 64–73. [Google Scholar]
- El Haddad, J.; Canioni, L.; Bousquet, B. Good Practices in LIBS Analysis: Review and Advices. Spectrochim. Acta Part B At. Spectrosc. 2014, 101, 171–182. [Google Scholar] [CrossRef] [Scilit]
- Burlet, C.; Stasi, G.; Pinkse, T.; Rossi, C. The ROBOMINERS LIBS Spectrometer: A Mining Sensor Prototype for Autonomous In-Stream, In-Slurry Geochemical Diagnostics. In Proceedings of the 7th International Geologica Belgica Meeting 2021: Geosciences Made in Belgium, Tervuren, Belgium, 15–17 September 2021; p. 239. [Google Scholar]
- Dvoynikov, M.; Ivanov, S.; Petrov, A. Developments Made in the Field of Drilling Fluids by Saint Petersburg Mining University. Int. J. Eng. 2020, 33, 686–691. [Google Scholar] [CrossRef] [Scilit]
- Wolf, J.-P. Ultraviolet/Visible Light Detection and Ranging Applications in Air Monitoring. In Encyclopedia of Analytical Chemistry; Meyers, R.A., Ed.; Wiley: Hoboken, NJ, USA, 2000; ISBN 9780471976707/9780470027318. [Google Scholar]
- Potts, P.J. Portable X-Ray Fluorescence Spectrometry: Capabilities for In Situ Analysis; Royal Society of Chemistry: Cambridge, UK, 2008; ISBN 9780854045525/9781847558640. [Google Scholar]
- Coffey, P.; Smith, N.; Lennox, B.; Kijne, G.; Bowen, B.; Davis-Johnston, A.; Martin, P.A. Robotic Arm Material Characterisation Using LIBS and Raman in a Nuclear Hot Cell Decommissioning Environment. J. Hazard. Mater. 2021, 412, 125193. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Liu, S.; Chen, R. Improved Rapid-Expanding-Random-Tree-Based Trajectory Planning on Drill ARM of Anchor Drilling Robots. Machines 2023, 11, 858. [Google Scholar] [CrossRef] [Scilit]
- Rahim, A.; Asif, M.; Awais, M.; Iqbal, S. Formal Analysis of Reconfigurable and Autonomous Robotic Arm. Preprint 2023. [Google Scholar] [CrossRef] [Scilit]
- Hong, Z.; Petillot, Y.; Wallace, A.; Wang, S. Radar SLAM: A robust SLAM system for all weather conditions. arXiv 2021, arXiv:2104.05347. [Google Scholar]




| Failure Scenario | Detected by | Immediate Action | Adaptive Strategy | Notification/Sync |
|---|---|---|---|---|
| No Suitable Deployment Site Found | Deployer | Pause deployment | Expand search area or reposition for new perspective | Notify dispatcher and await instructions |
| Stinger Retrieval Failure | Deployer | Attempt regrasp or reposition | Request supplier to provide another unit | Notify dispatcher; update shared state |
| Deployment Misalignment | Deployer | Abort deployment | Reposition and attempt precise placement again | Notify stinger and update placement status |
| Anchoring Failure (Unstable Terrain) | Stinger | Abort anchoring | Request repositioning to alternate site | Notify deployer |
| Resource Supply Delay or Fault | Stinger/deployer | Retry request for resources | Switch supplier (if available), reschedule operation | Notify dispatcher |
| Drilling Head Jam or Tool Failure | Stinger | Halt drilling, disengage tool | Attempt self-repair or request tool replacement | Notify deployer and dispatcher |
| Material Too Hard/Unexpected Composition | Stinger | Pause drilling | Adjust drilling parameters or change bit/tool | Share data with team for future planning |
| Communication Drop | Any agent | Retry communication | Attempt mesh reconnection or fallback protocol | Alert dispatcher if timeout exceeds threshold |
| Incomplete Drilling at Site | Stinger | Request repositioning | Deployer relocates robot to alternate site | Confirm new plan with all agents |
| Repositioning Failure (e.g., Terrain Obstacle) | Deployer | Abort current path | Plan alternative route using updated map | Notify stinger and dispatcher |
| Mission Phase Validation Timeout | Any agent | Trigger safe state | Retry validation; if failure persists, notify team | Alert dispatcher and wait for manual override |
| Parameter | LIBS | XRF | Mass Spectrometry (e.g., ICP-MS) |
|---|---|---|---|
| Sample preparation | Minimal or none | Minimal (flattening, drying, grinding) | Complex (acid digestion, filtration) |
| Acquisition time | Seconds (1–10 s) | Tens of seconds | Minutes (plus extensive sample preparation) |
| Detection limits | ppm level (matrix-dependent) | sub-ppm to ppm | sub-ppb to ppm |
| Accuracy | Moderate (±5–20%) | High (±1–5%) | Very high (±0.1–1%) |
| Portability | High (robot-compatible, compact) | Moderate (handheld units available) | Very low (lab-based only) |
| Light element detection (e.g., Li) | Yes (effective for low-Z elements) | Limited (detection drops for Z < 11) | Yes |
| Radiation safety | No special restrictions | Requires control of ionizing radiation | No (chemical hazards apply) |
| In situ/robotic integration | Excellent (already field-tested) | Limited (requires stability and contact) | Not applicable |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).
Share and Cite
Nikolakopoulos, G.; Koval, A.; Fumagalli, M.; Konieczna-Fuławka, M.; Santas Moreu, L.; Vigara-Puche, V.; Verma, K.; Waard, B.d.; Deutsch, R. Autonomous Drilling and the Idea of Next-Generation Deep Mineral Exploration. Sensors 2025, 25, 3953. https://doi.org/10.3390/s25133953
Nikolakopoulos G, Koval A, Fumagalli M, Konieczna-Fuławka M, Santas Moreu L, Vigara-Puche V, Verma K, Waard Bd, Deutsch R. Autonomous Drilling and the Idea of Next-Generation Deep Mineral Exploration. Sensors. 2025; 25(13):3953. https://doi.org/10.3390/s25133953
Chicago/Turabian StyleNikolakopoulos, George, Anton Koval, Matteo Fumagalli, Martyna Konieczna-Fuławka, Laura Santas Moreu, Victor Vigara-Puche, Kashish Verma, Bob de Waard, and René Deutsch. 2025. "Autonomous Drilling and the Idea of Next-Generation Deep Mineral Exploration" Sensors 25, no. 13: 3953. https://doi.org/10.3390/s25133953
APA StyleNikolakopoulos, G., Koval, A., Fumagalli, M., Konieczna-Fuławka, M., Santas Moreu, L., Vigara-Puche, V., Verma, K., Waard, B. d., & Deutsch, R. (2025). Autonomous Drilling and the Idea of Next-Generation Deep Mineral Exploration. Sensors, 25(13), 3953. https://doi.org/10.3390/s25133953



