Article

Study on Creepage Control for PLS-160 Wheel–Rail Adhesion Test Rig Based on LADRC

Institute of Rail Transit, Tongji University, Shanghai 201804, China
*
Author to whom correspondence should be addressed.
Sensors 2023, 23(4), 1792; https://doi.org/10.3390/s23041792
Submission received: 1 December 2022 / Revised: 27 January 2023 / Accepted: 2 February 2023 / Published: 5 February 2023
(This article belongs to the Topic Industrial Control Systems)

Abstract

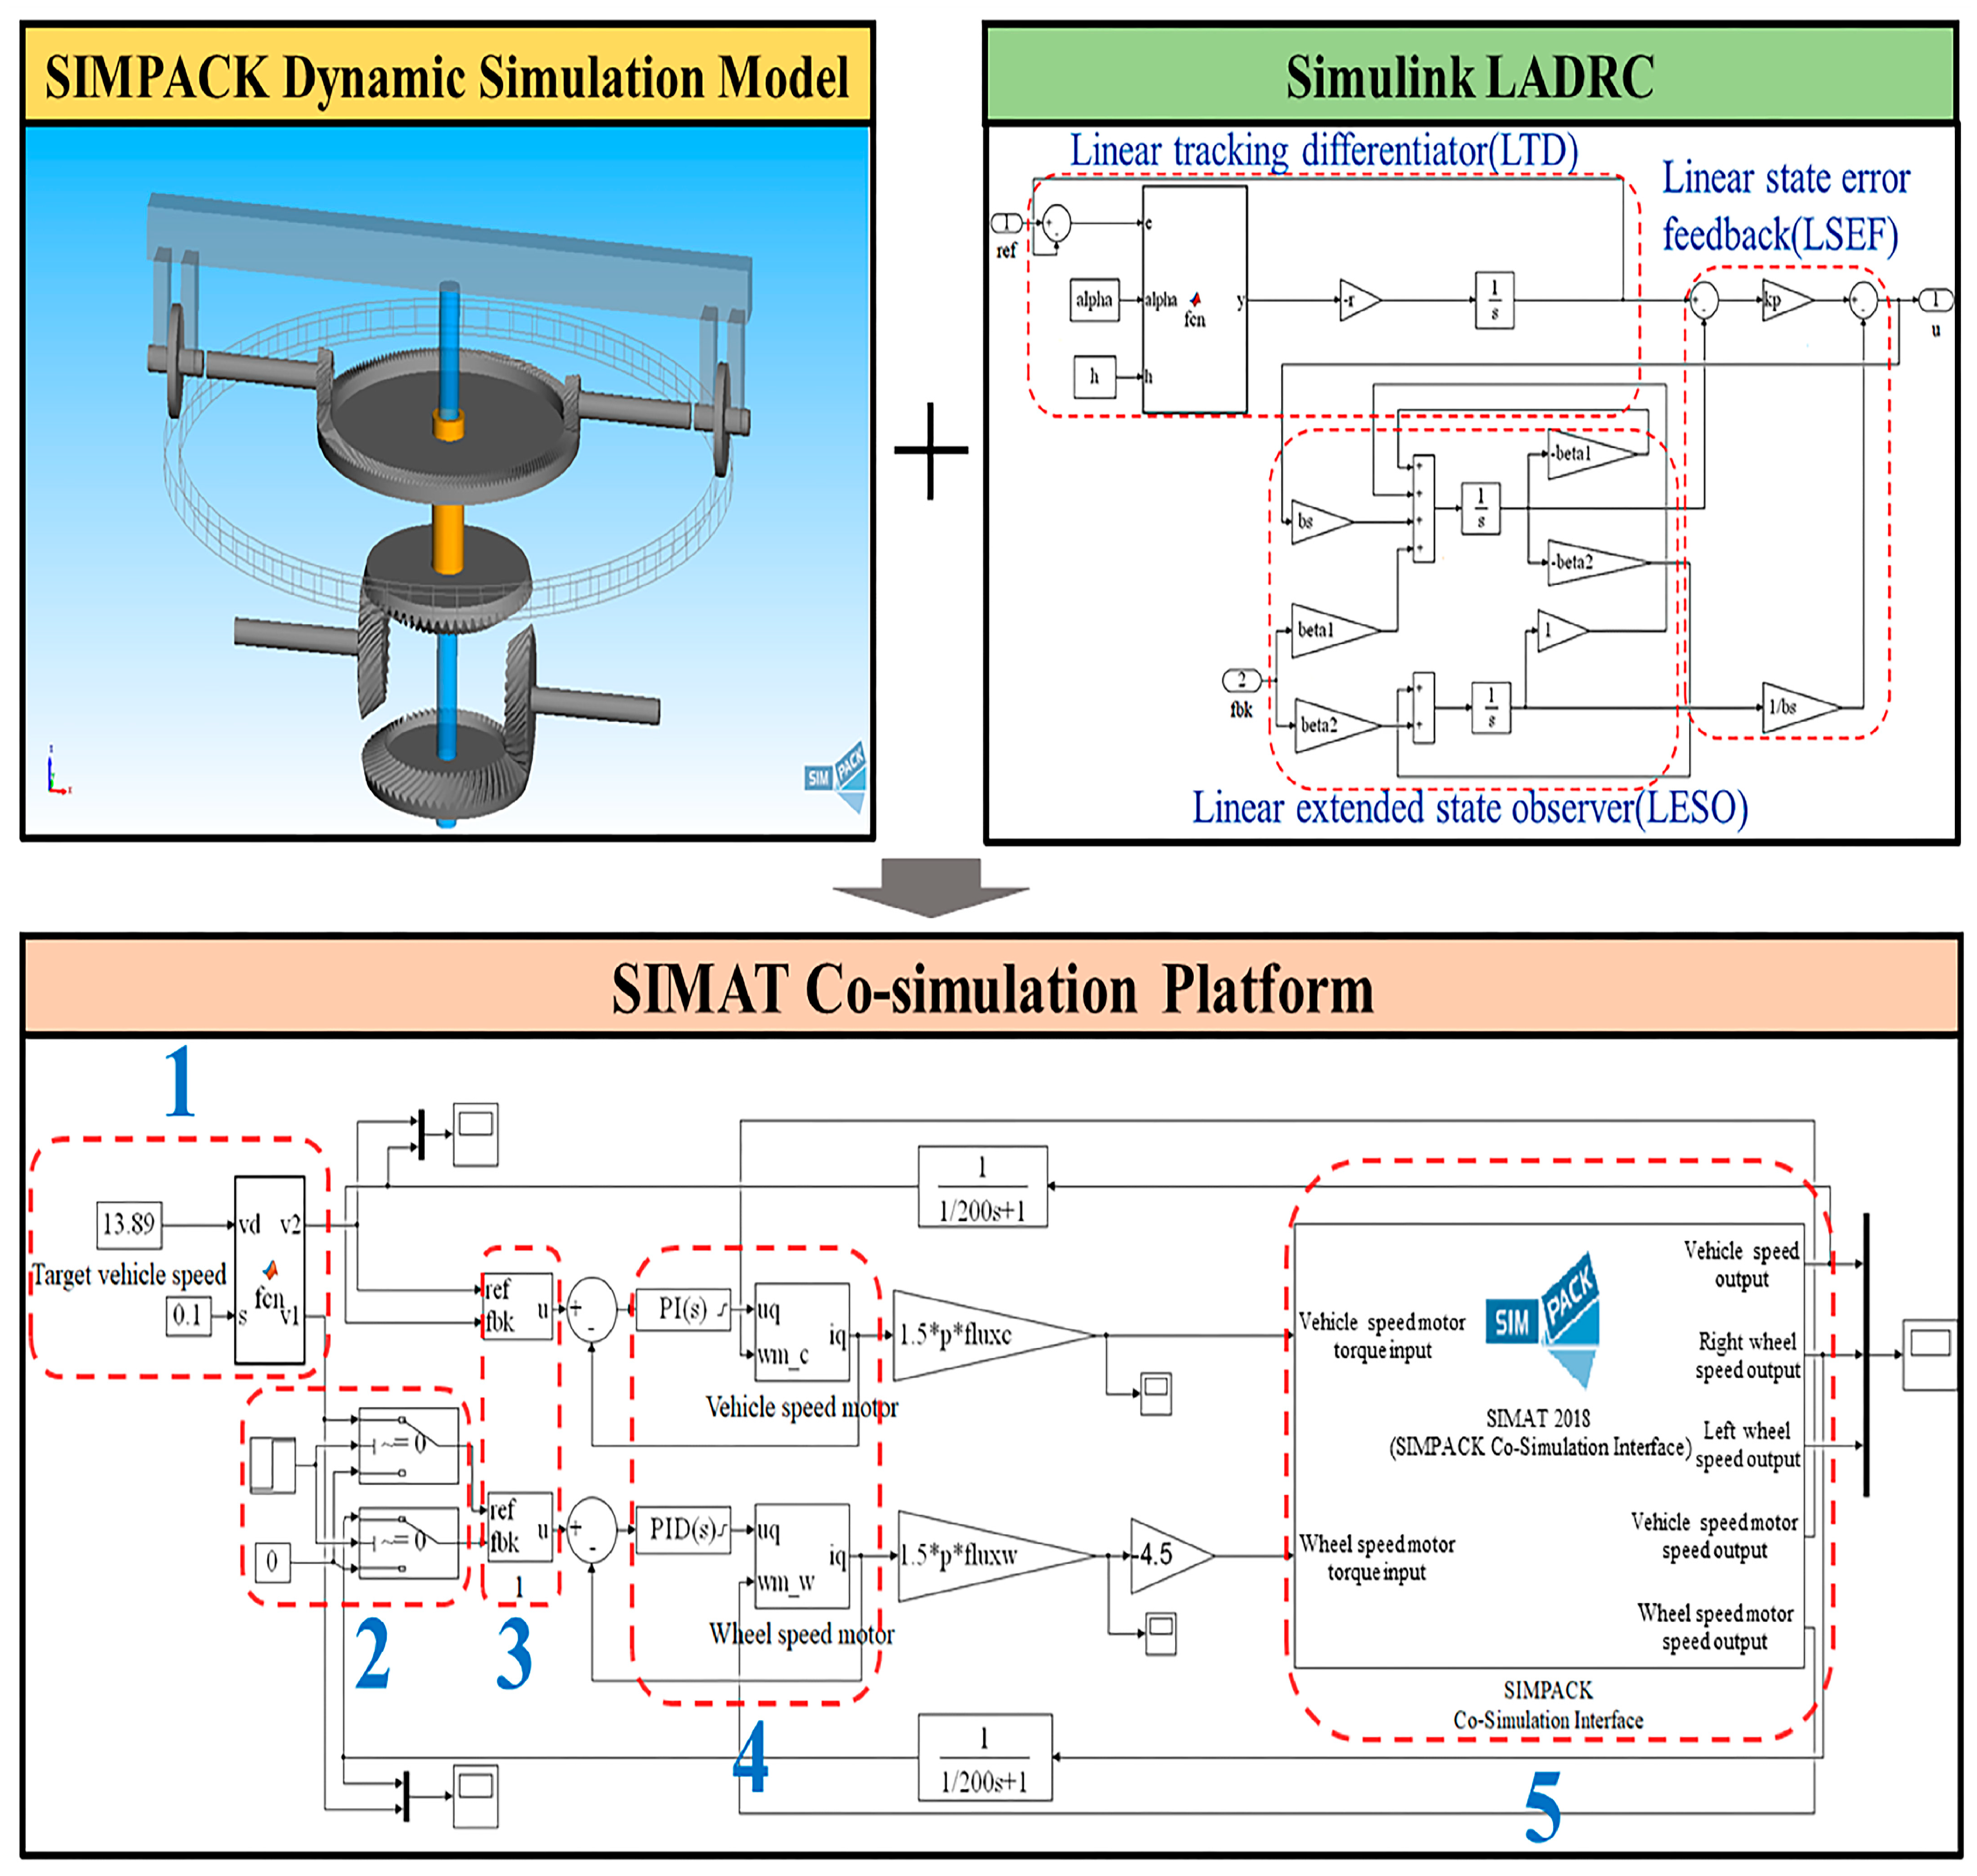
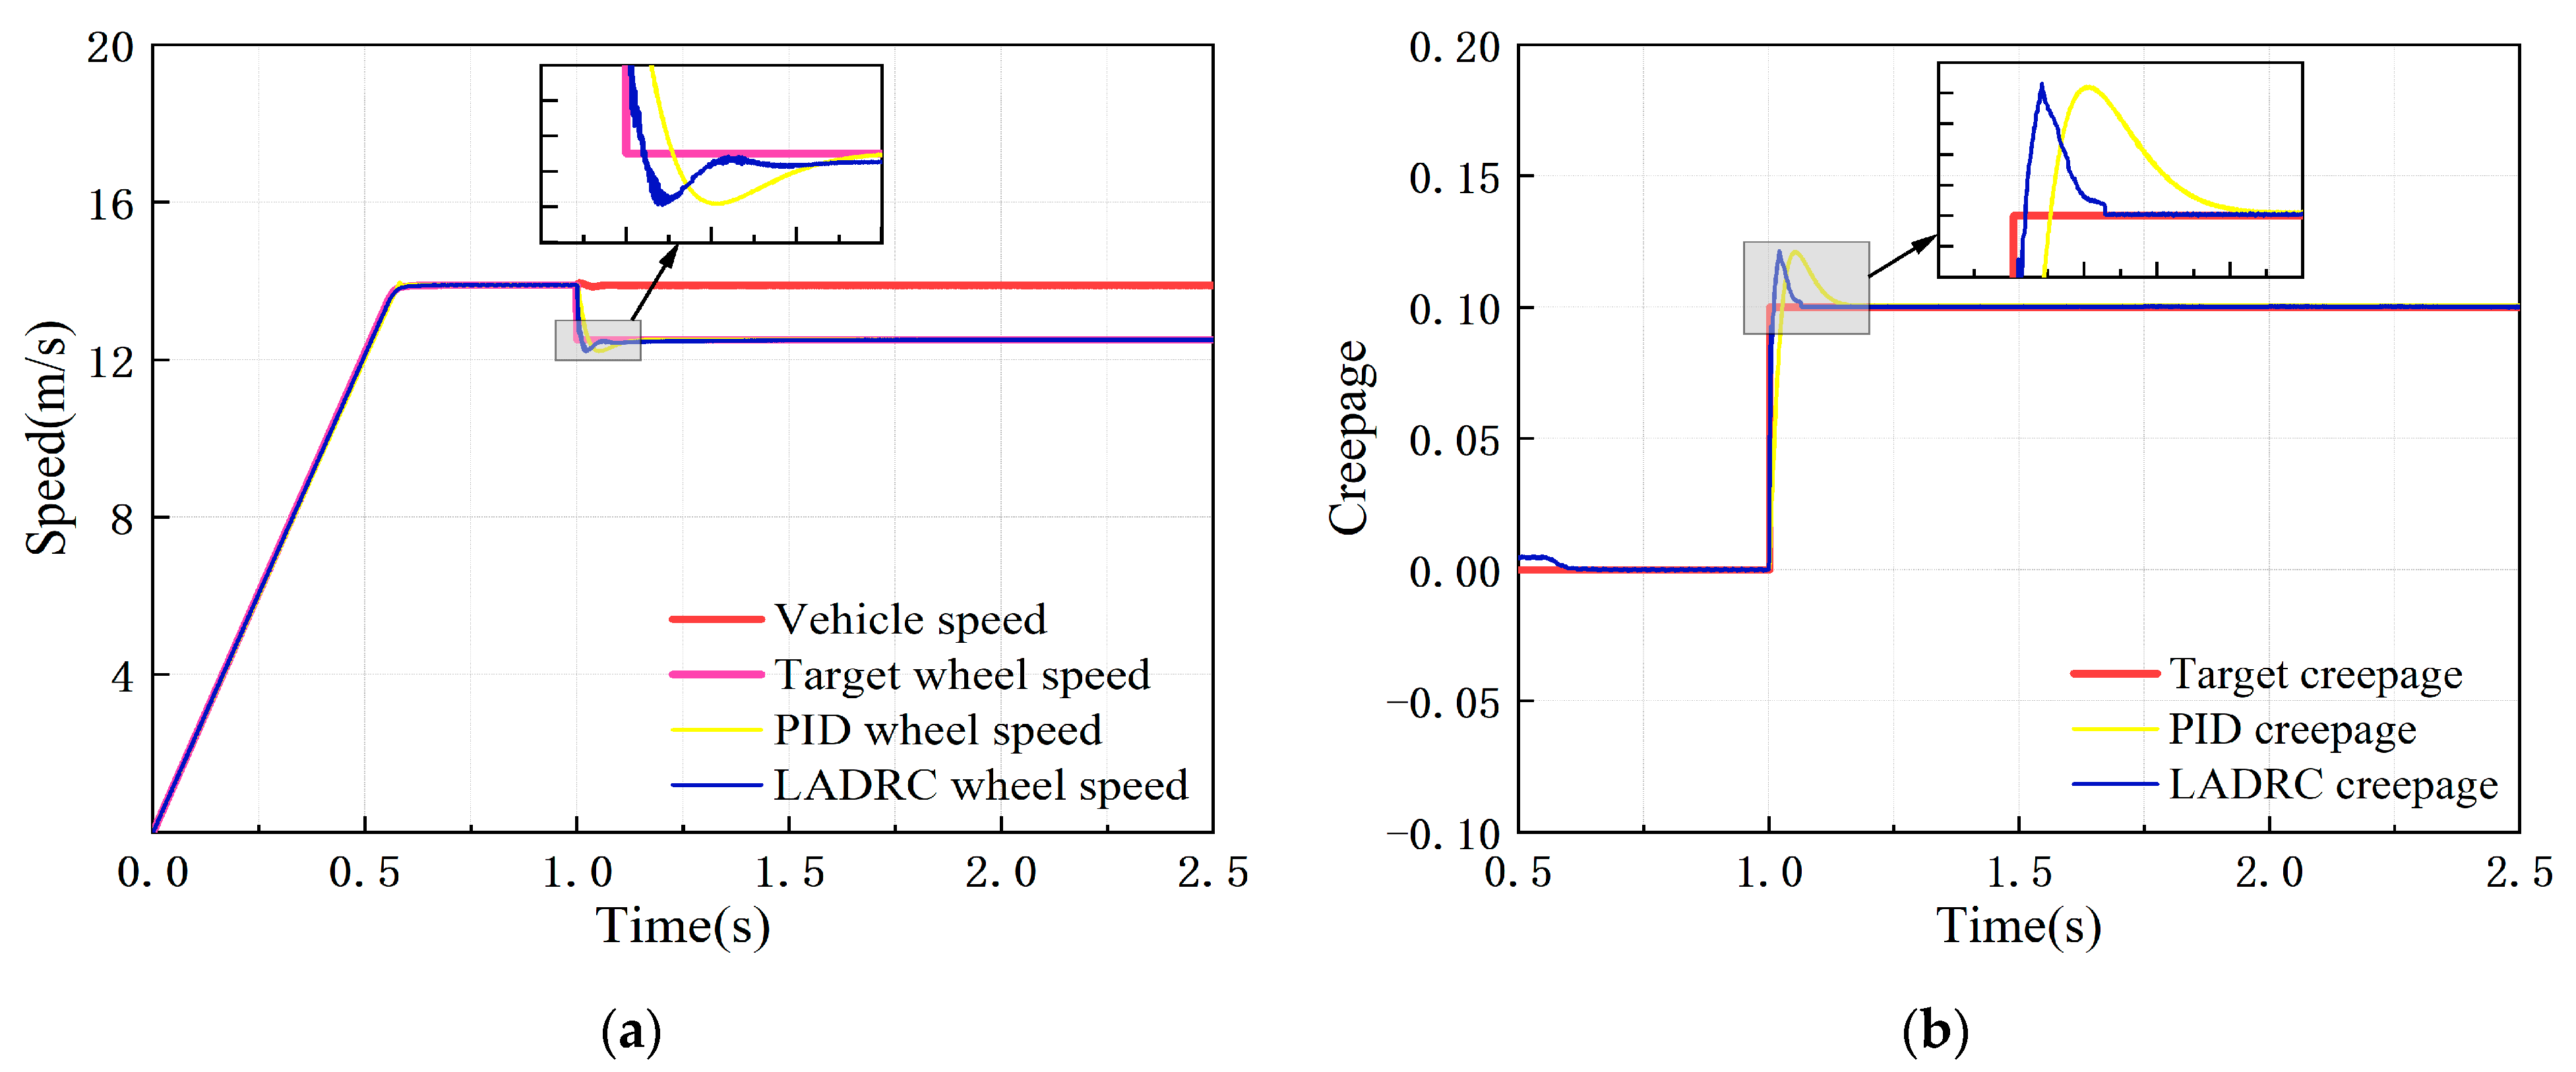
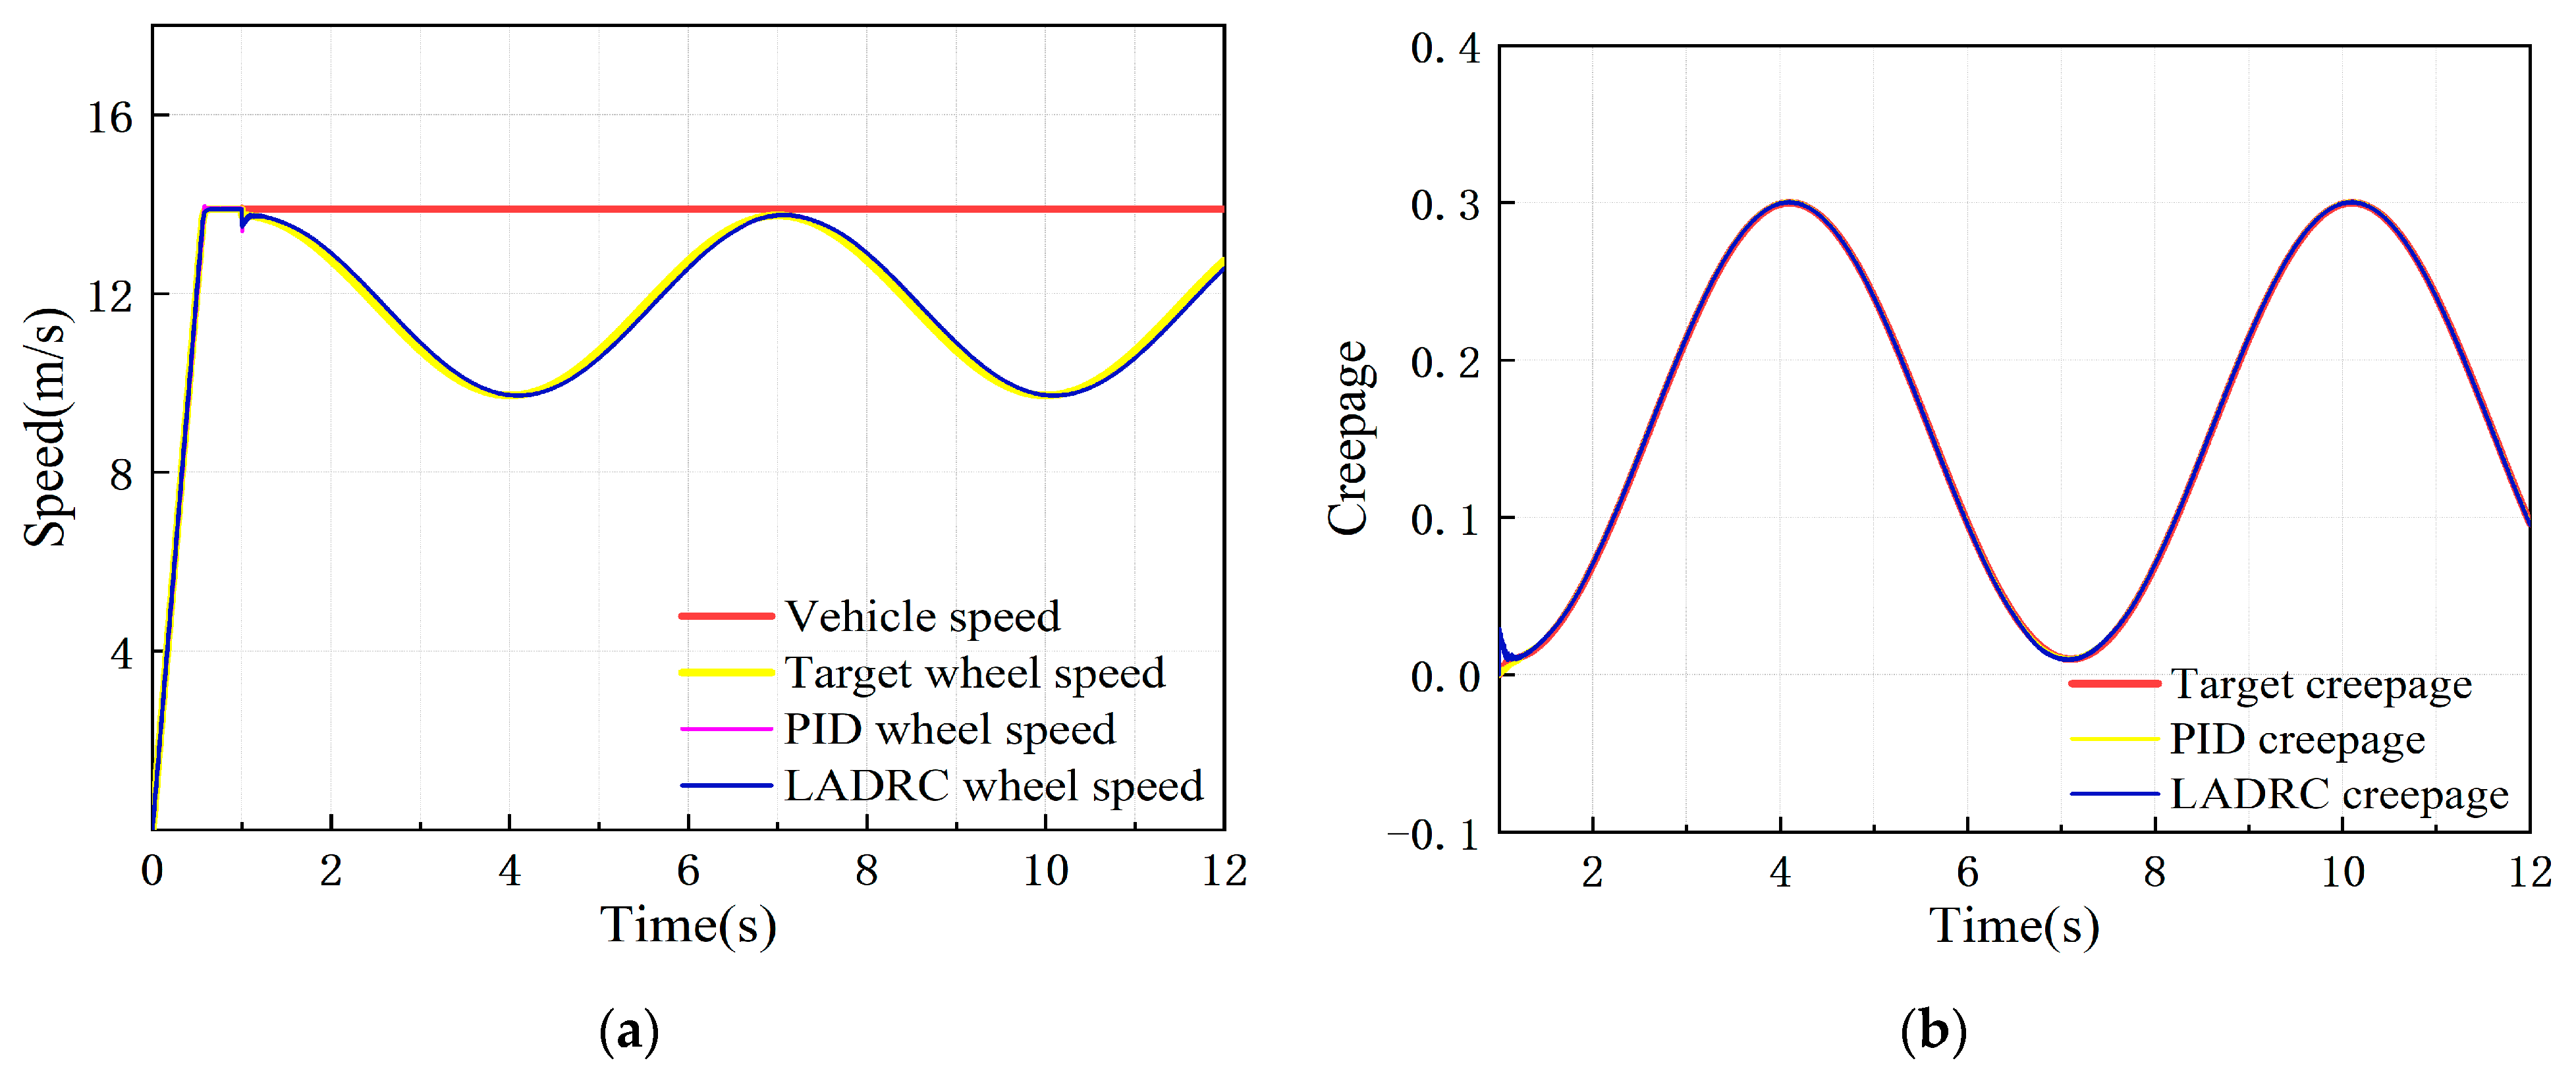
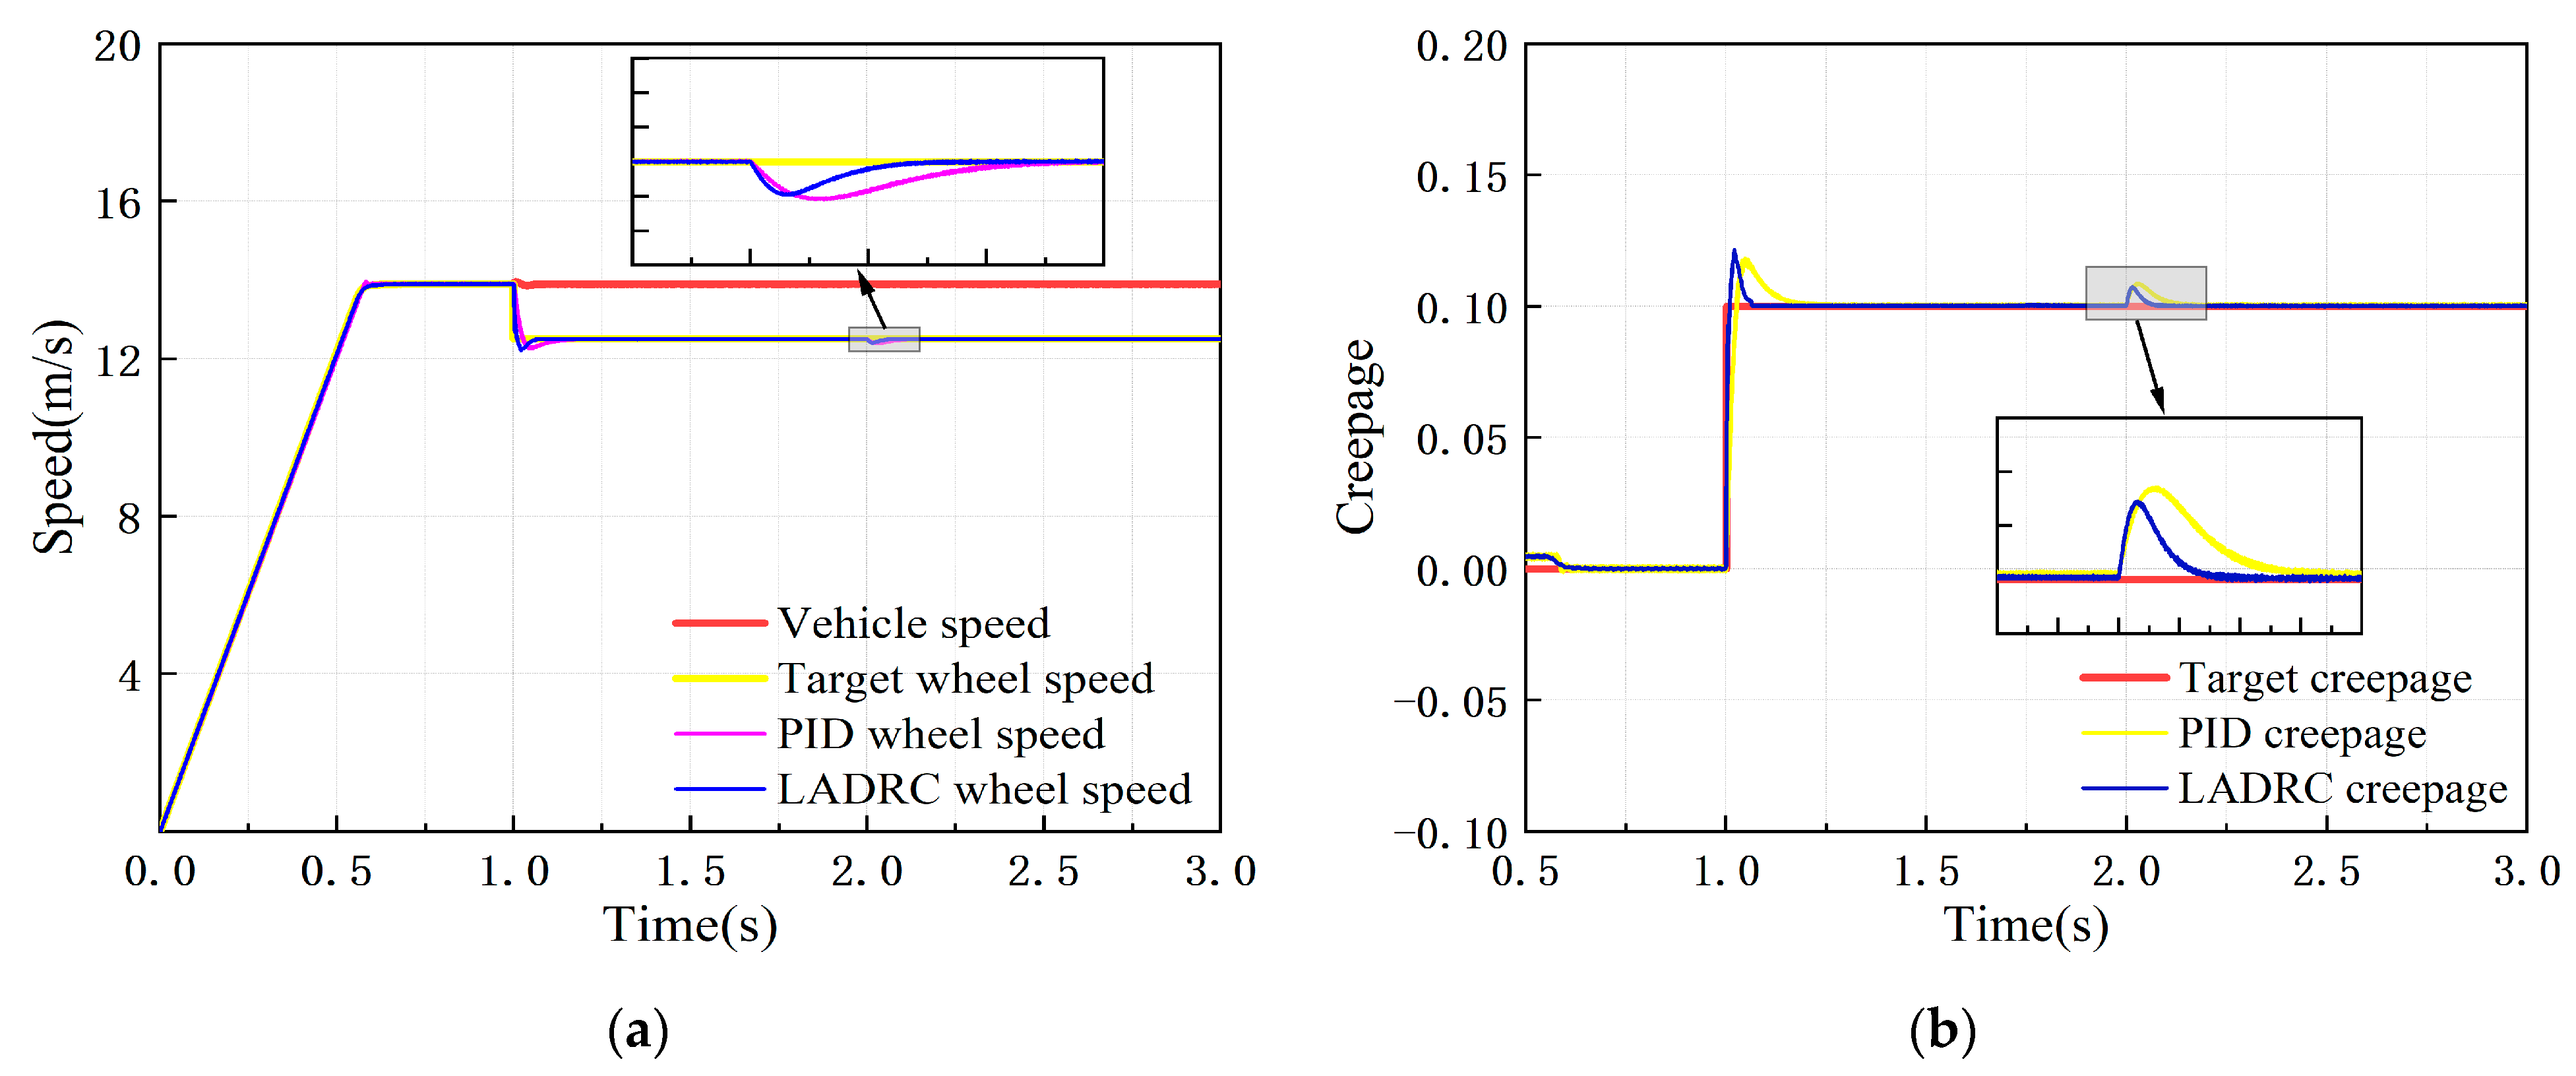
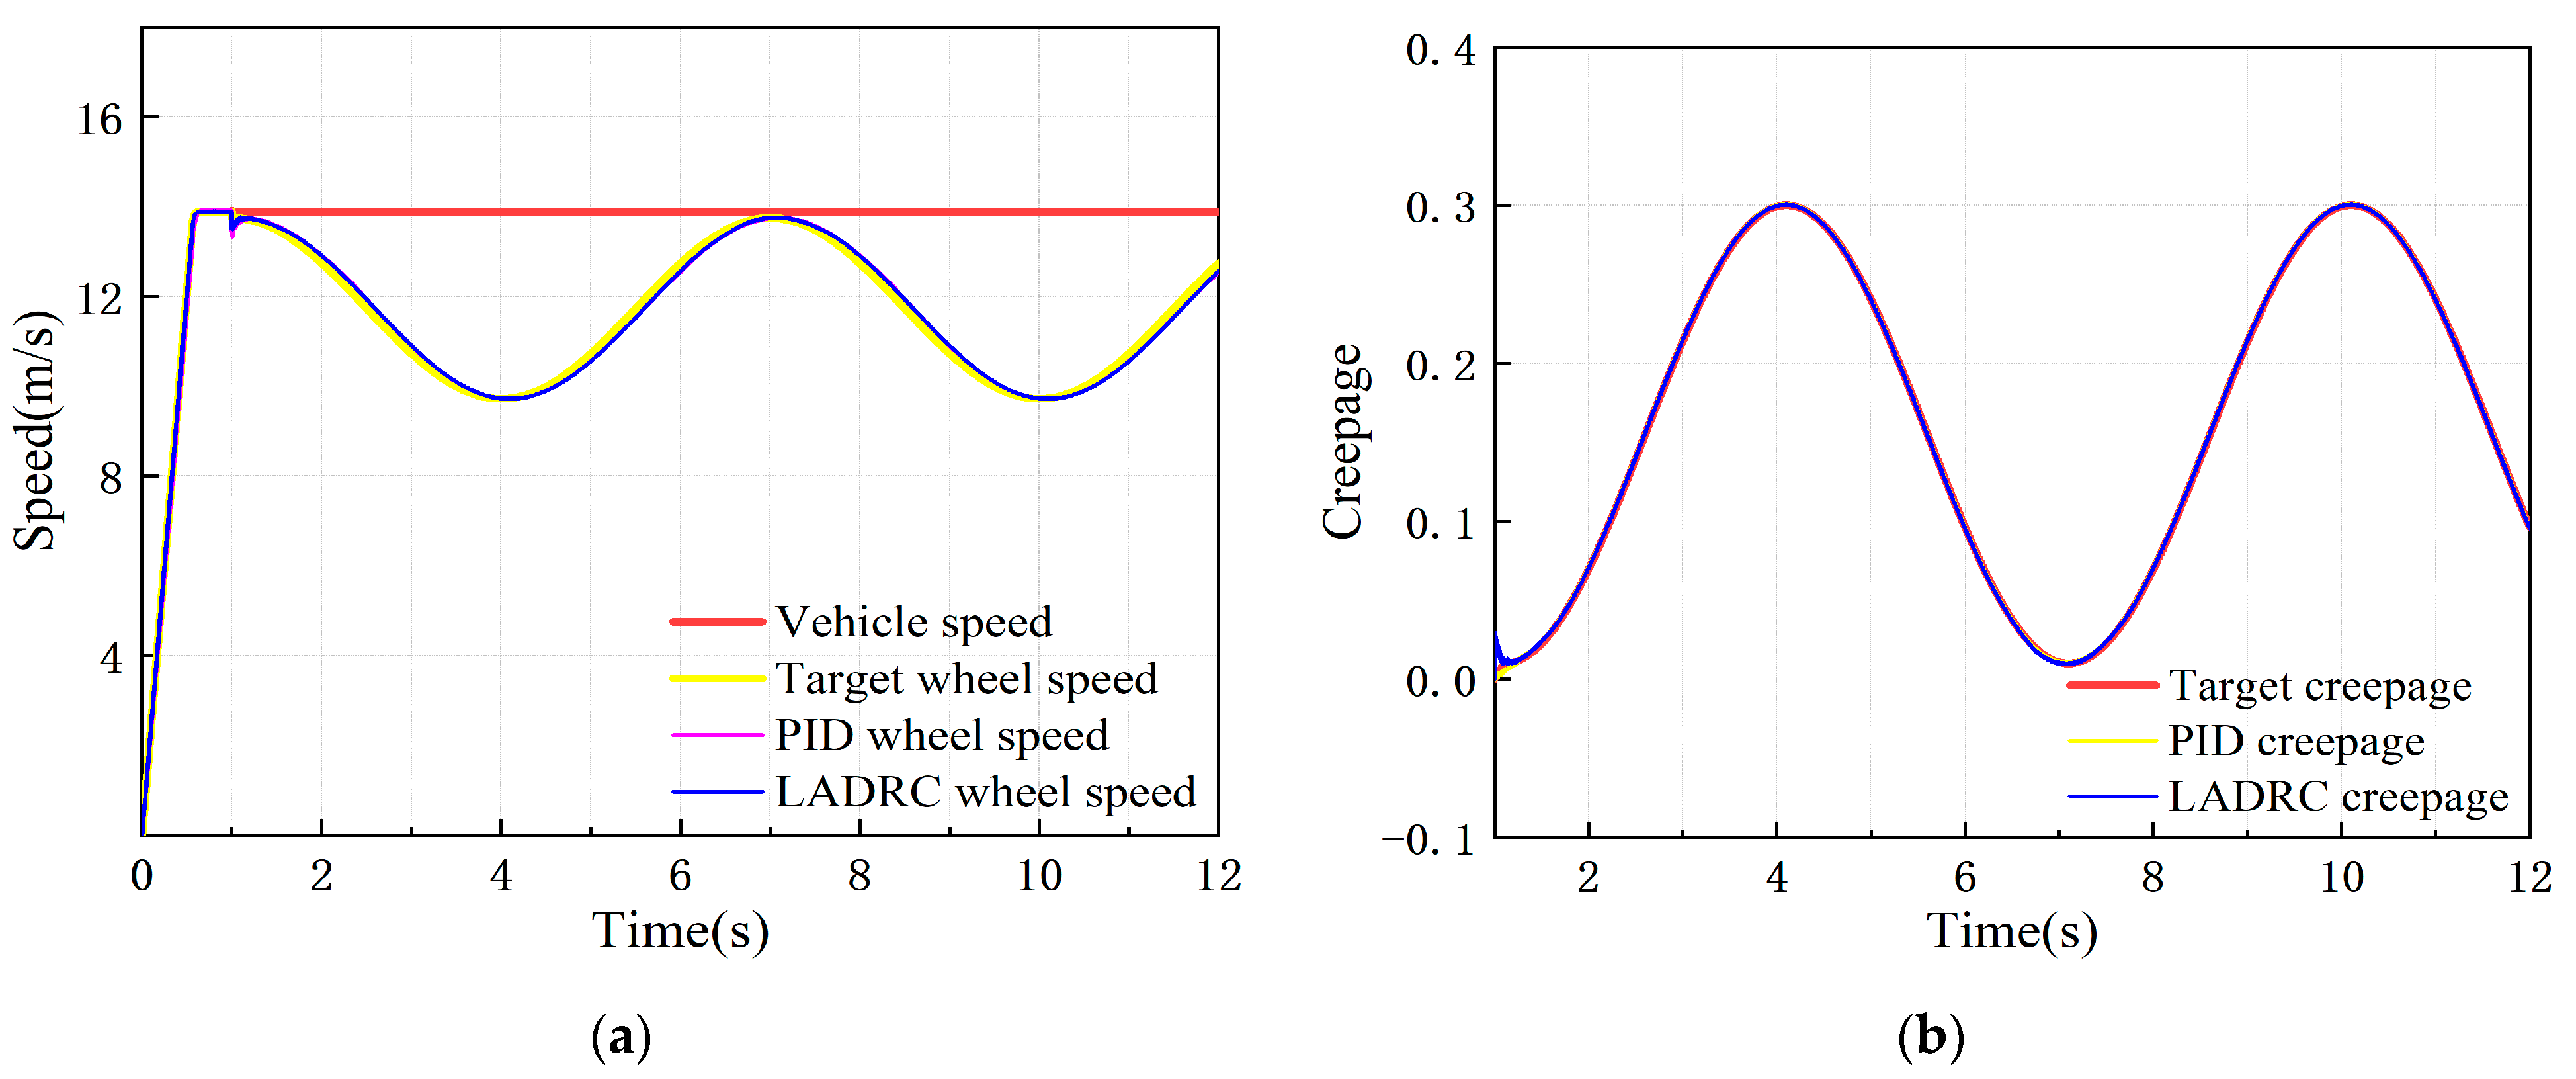
Aiming at the problem of low control accuracy caused by nonlinear disturbances in the operation of the PLS-160 wheel–rail adhesion test rig, a linear active disturbance rejection controller (LADRC) suitable for the wheel–rail adhesion test rig was designed. The influence of nonlinear disturbances during the operation of the test rig on the control accuracy was analyzed based on SIMPACK. The SIMAT co-simulation platform was established to verify the control performance of the LADRC designed in this paper. The simulation results show that the speed and creepage errors of the test rig under the control of the LADRC met the adhesion test technical indicators under four different conditions. Compared with the traditional PID controller, the creepage overshoot and response time with the LADRC were reduced by 1.27% and 60%, respectively, under the constant creepage condition, and the stability recovery time was shorter under the condition of a sudden decrease in the adhesion coefficient. The LADRC designed in this paper shows better dynamic and anti-interference performance; therefore, it is more suitable for a follow-up study of the PLS-160 wheel–rail adhesion test rig.
Keywords: PLS-160 wheel–rail adhesion test rig; nonlinear disturbance; linear active disturbance rejection controller; co-simulation; creepage control PLS-160 wheel–rail adhesion test rig; nonlinear disturbance; linear active disturbance rejection controller; co-simulation; creepage control