Article

Modular Robotic Limbs for Astronaut Activities Assistance
1
State Key Laboratory of Robotics and Systems, Harbin Institute of Technology, Harbin 150001, China
2
Institute of Systems Engineering, China Academy of Engineering Physics, Mianyang 621900, China
*
Author to whom correspondence should be addressed.
Sensors 2021, 21(18), 6305; https://doi.org/10.3390/s21186305
Submission received: 22 July 2021 / Revised: 3 September 2021 / Accepted: 18 September 2021 / Published: 21 September 2021
(This article belongs to the Section Sensors and Robotics)

Abstract

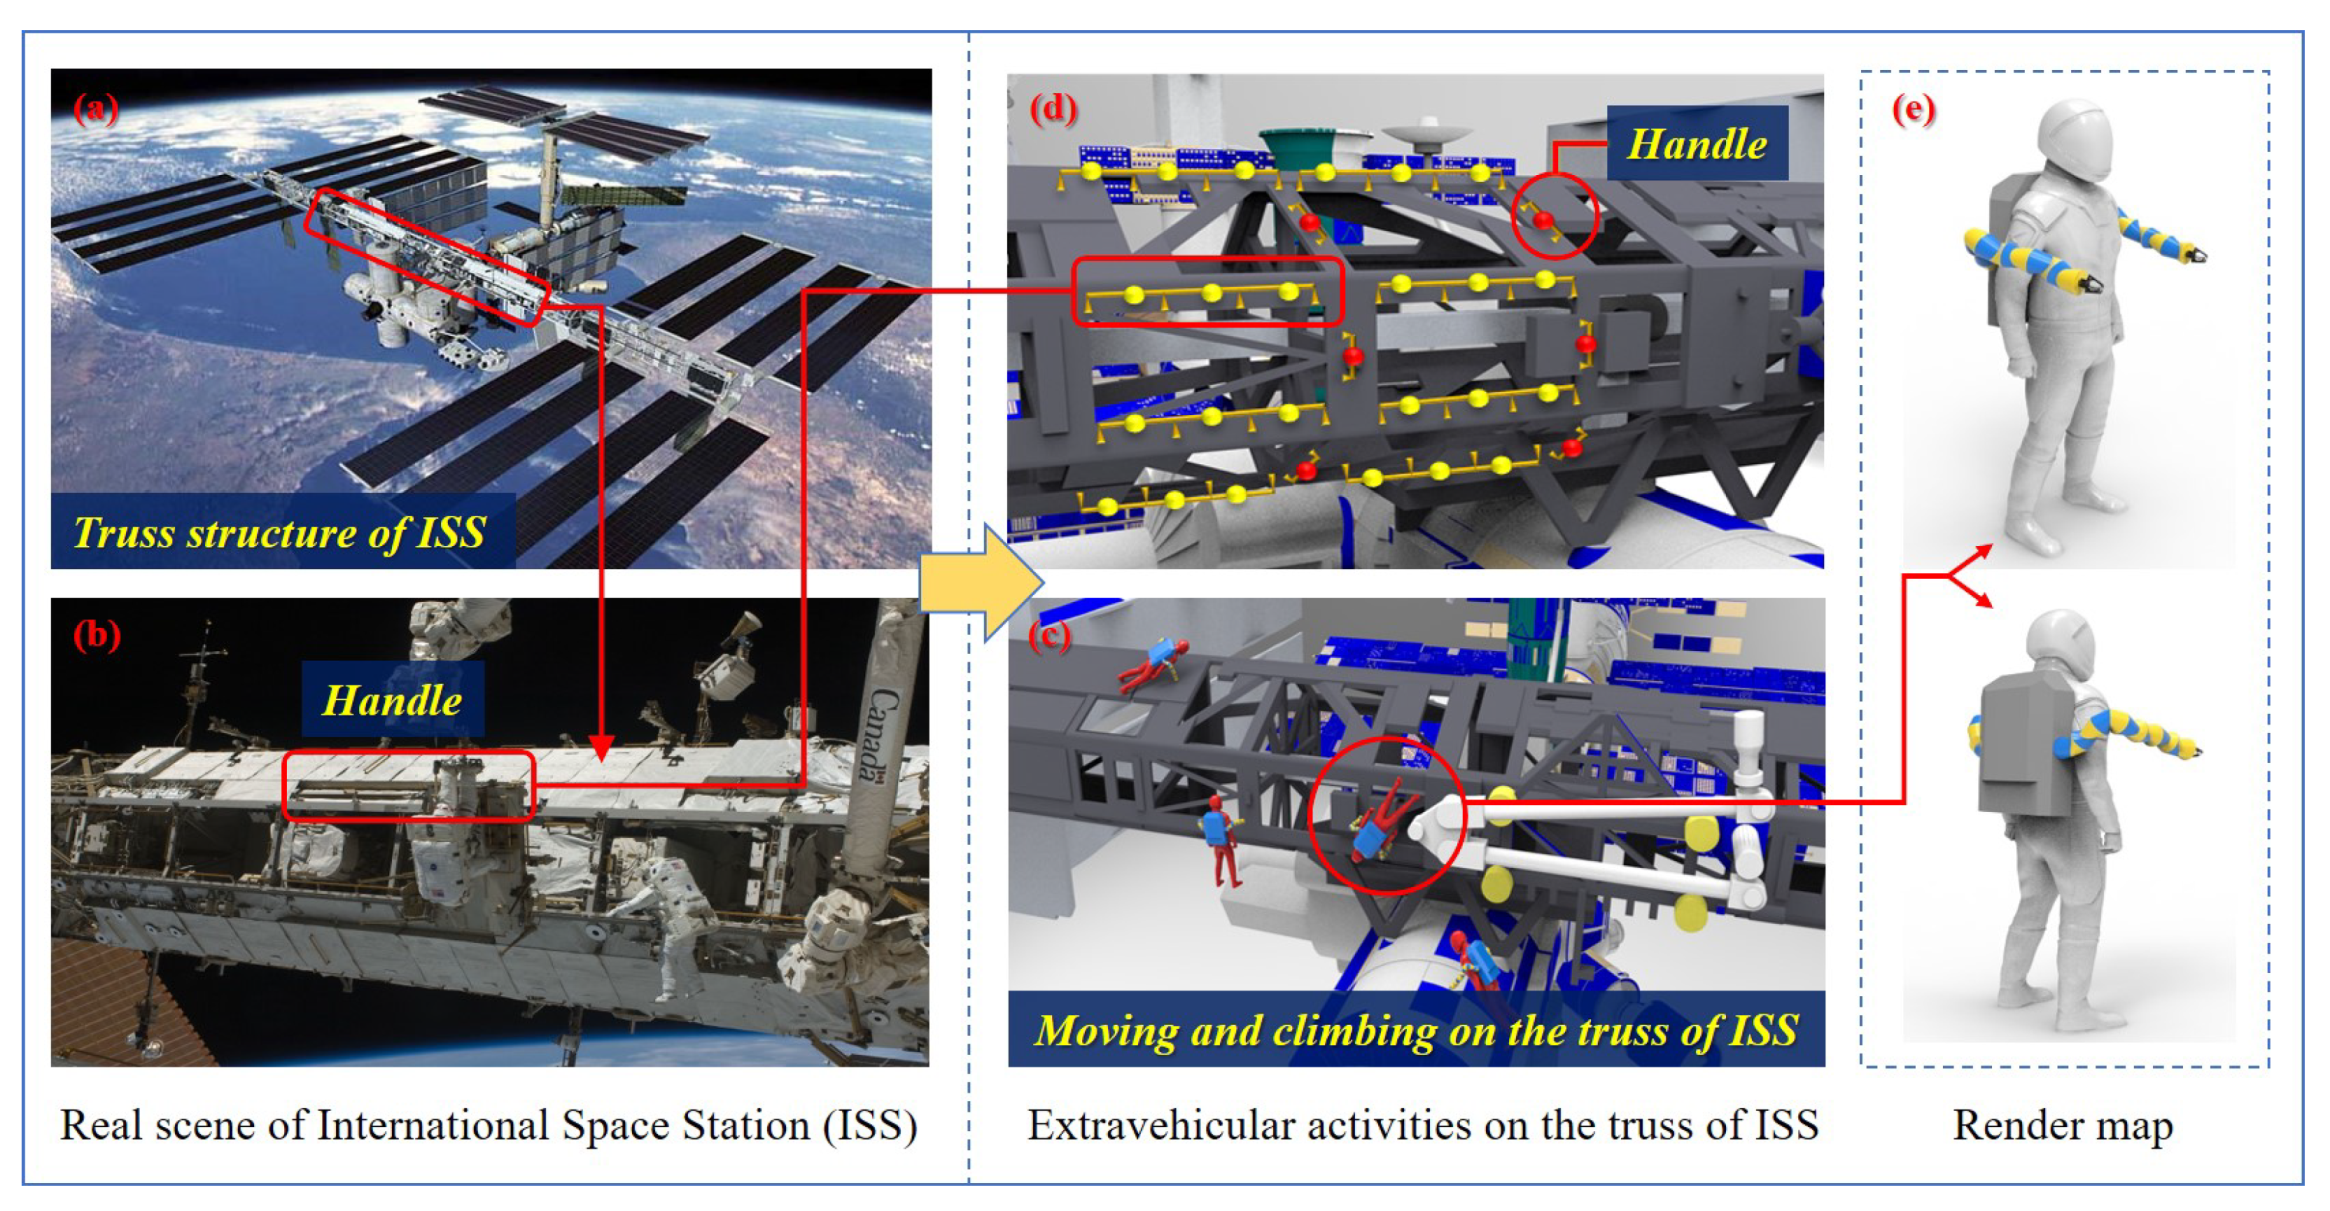
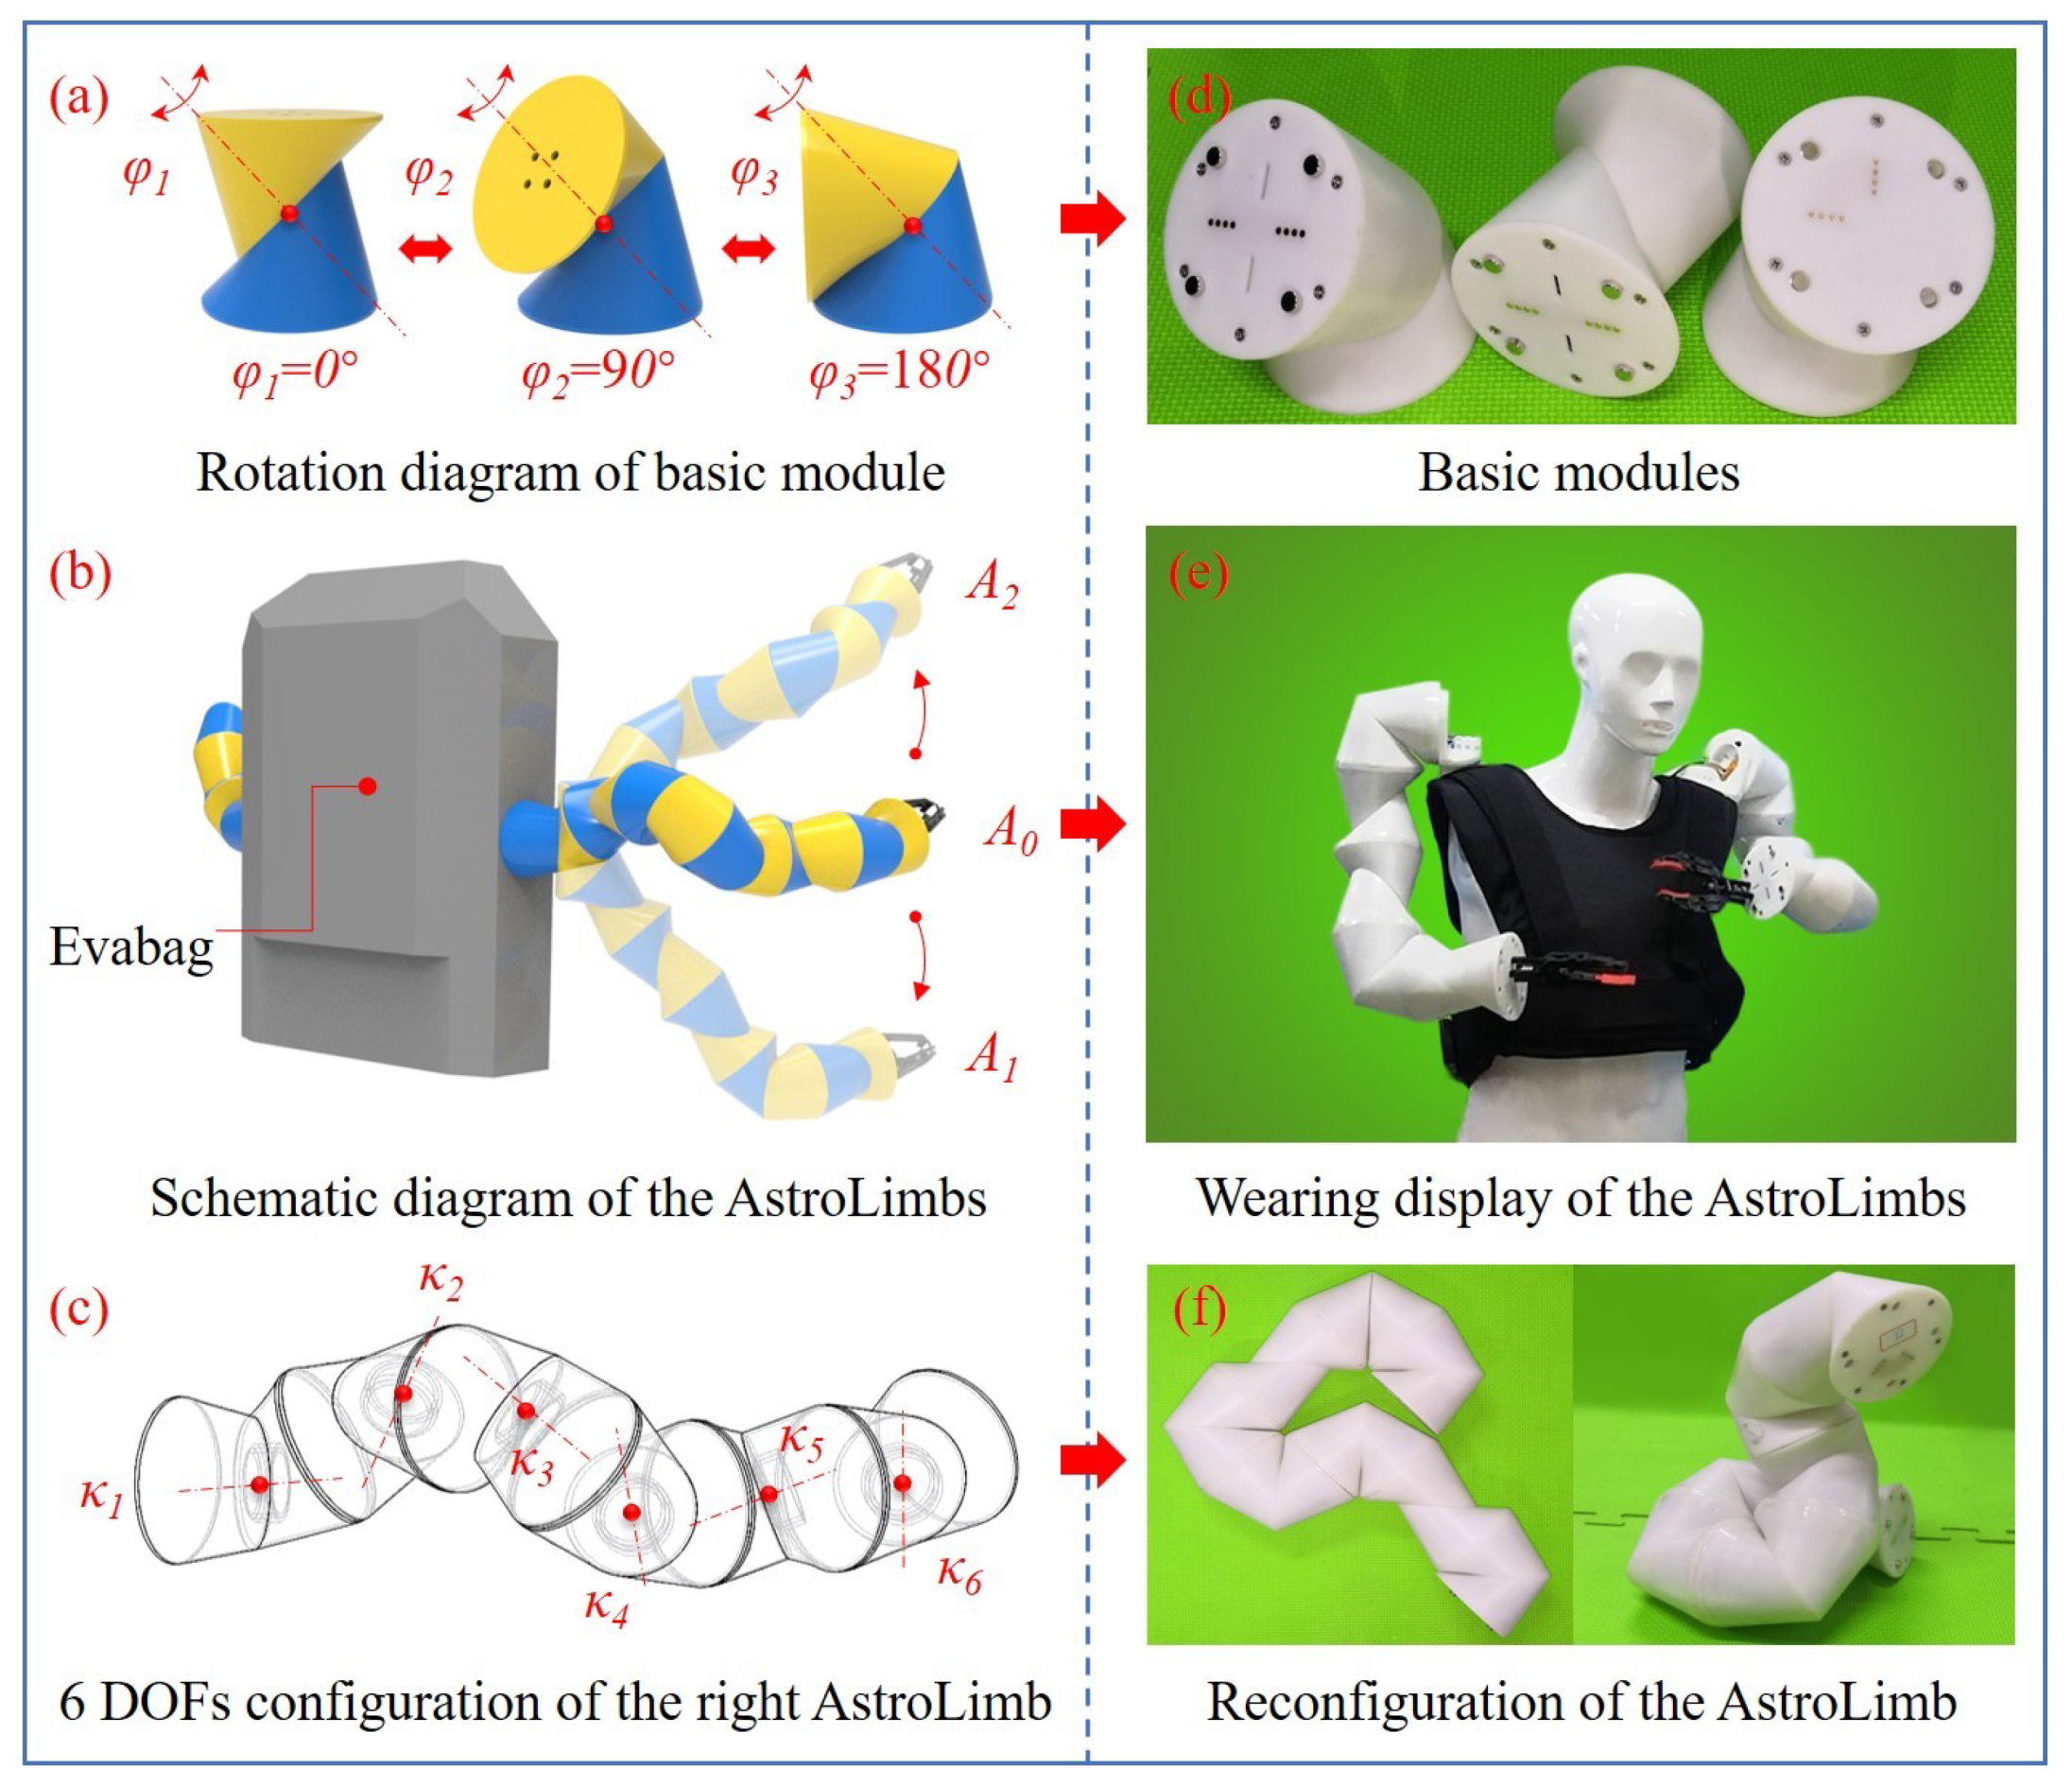
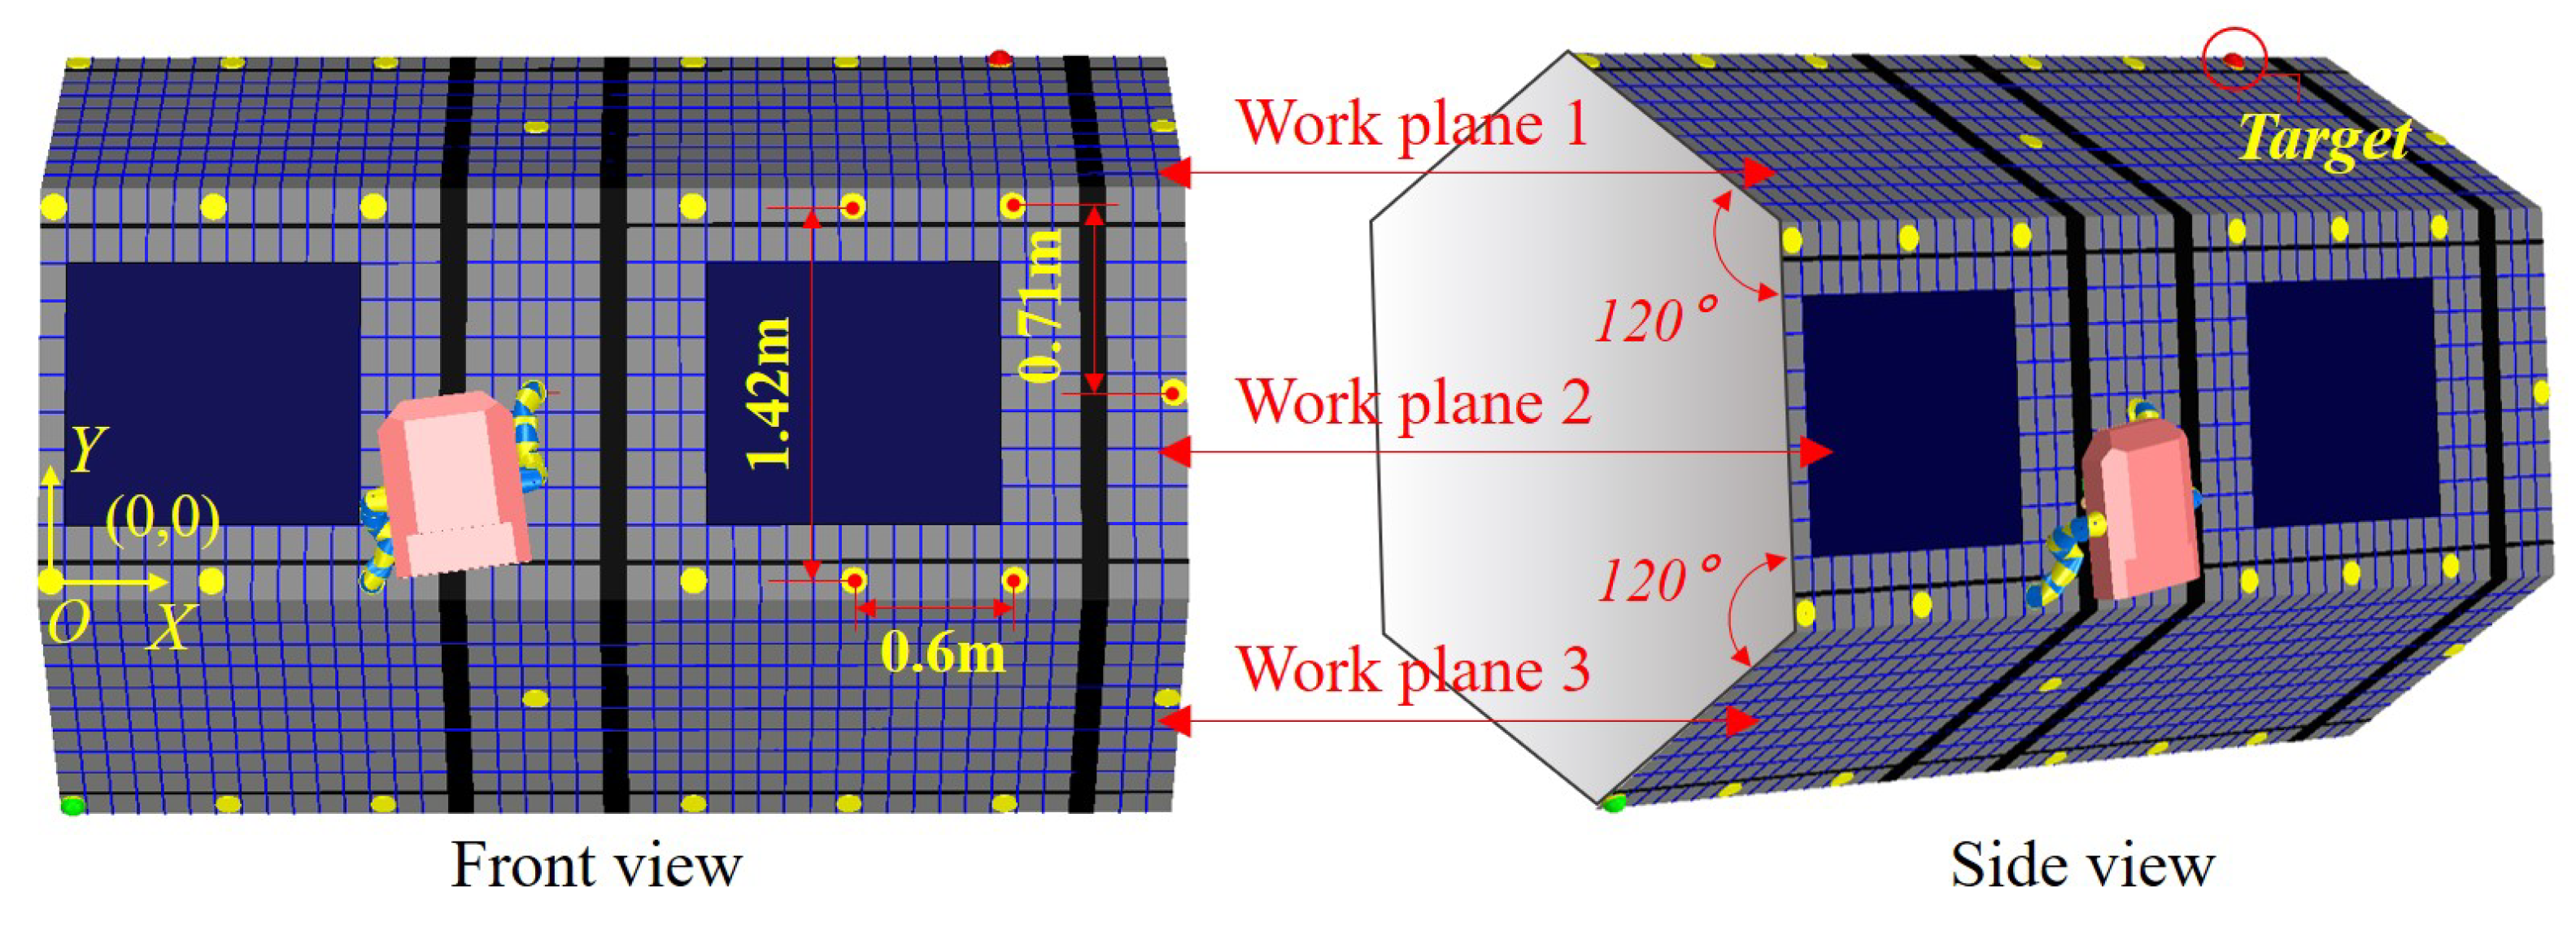
In order to meet the assist requirements of extravehicular activity (EVA) for astronauts, such as moving outside the international space station (ISS) or performing on-orbit tasks by a single astronaut, this paper proposes an astronaut robotic limbs system (AstroLimbs) for extravehicular activities assistance. This system has two robotic limbs that can be fixed on the backpack of the astronaut. Each limb is composed of several basic module units with identical structure and function, which makes it modularized and reconfigurable. The robotic limbs can work as extra arms of the astronaut to assist them outside the space station cabin. In this paper, the robotic limbs are designed and developed. The reinforcement learning method is introduced to achieve autonomous motion planning capacity for the robot, which makes the robot intelligent enough to assist the astronaut in unstructured environment. In the meantime, the movement of the robot is also planned to make it move smoothly. The structure scene of the ISS for extravehicular activities is modeled in a simulation environment, which verified the effectiveness of the proposed method.
Keywords: astronaut operation; extravehicular activities assistance; robotic limbs; modular robots; wearable robots; reinforcement learning astronaut operation; extravehicular activities assistance; robotic limbs; modular robots; wearable robots; reinforcement learning