


Abstract
Wireless links in underground coal mines suffer from severe attenuation, blockage, and limited spatial coverage. To improve link quality under these conditions, we study a simultaneously transmitting and reflecting reconfigurable intelligent surface (STAR-RIS)-assisted system with multiple movable antennas (MAs) installed at the base station (BS) panel. Unlike prior models that assume a continuous movement box, we explicitly account for practical panel constraints: mechanical supports and RF feed lines partition the BS panel into non-overlapping irregular feasible subregions. This turns the BS-side antenna-positioning task into a mixed-integer nonlinear program (MINLP). We formulate a joint optimization problem that couples BS beamforming, STAR-RIS transmission/reflection coefficients, BS-side MA positions, and MA-to-subregion assignment with collision-avoidance constraints. To solve it, we adopt a block coordinate descent (BCD) framework: successive convex approximation (SCA) for beamforming, semidefinite relaxation (SDR)-based updates for STAR-RIS coefficients, and a penalty-based continuous relaxation for MINLP handling. The MA solver further integrates Hungarian initialization, cross-region jump updates, and reassignment corrections to escape poor local subregions. Simulation results in coal mine channel settings show that the proposed method yields a 66.7% sum-rate gain over fixed-antenna baselines and reduces required transmit power by 16.8 dB at the target-rate operating point. Compared with a regular-region BS-MA baseline, the irregular-partition design achieves an additional 5.6 dB power saving, demonstrating the practical value of hardware-aware geometry modeling.
1. Introduction
Underground coal mine communication networks must operate in environments characterized by strong attenuation, frequent blockage, and stringent safety requirements [1,2,3,4]. These conditions make stable wide-area wireless coverage difficult, especially when mobile underground devices rely on limited antenna hardware [5,6,7,8]. Therefore, communication designs for coal mines should not only pursue throughput, but also explicitly incorporate deployment constraints and propagation penalties into the optimization model.
Reconfigurable intelligent surfaces (RISs) can reshape propagation and improve effective channel gains [9,10]. In particular, STAR-RIS extends conventional reflection-only RIS by simultaneously supporting transmission and reflection [11,12,13,14,15,16], which is attractive for tunnel intersections and multi-branch roadway layouts [17]. In parallel, movable-antenna (MA) techniques provide an additional spatial degree of freedom by adapting antenna positions according to channel conditions [18,19,20,21,22,23,24,25,26,27,28]. However, existing STAR-RIS/MA studies typically assume idealized MA feasible regions (e.g., continuous rectangular domains) and often focus on user-side mobility [29,30,31].
These assumptions are weak for coal-mine-oriented BS deployments: BS panels must host mechanical supports and RF feed structures, which naturally split the panel into irregular non-contiguous subregions. Once this hardware reality is considered, MA positioning is no longer a simple projected-gradient problem; it becomes a constrained assignment-coupled MINLP, which necessitates a specialized solution approach.
Table 1 summarizes representative works on RIS-assisted MA systems. Two observations stand out. First, no existing work simultaneously considers BS-side MAs, STAR-RIS, and hardware-constrained irregular subregion deployment. Second, prior works uniformly assume continuous or regular feasible regions, bypassing the MINLP structure that arises from practical panel constraints. The proposed work addresses both gaps in the context of coal mine communications.
Table 1.
Comparison of representative STAR-RIS and movable antenna works.
In this paper, we study a STAR-RIS-assisted coal mine communication system with multiple BS-side MAs under hardware-constrained deployment geometry [32,33,34,35,36]. Underground Internet of Things (IoT) devices are equipped with fixed antennas, which is practically justified by the harsh underground conditions—severe vibration, battery constraints, and limited device space—that preclude mechanical antenna repositioning at the user side [37,38].
The main contributions of this paper are summarized as follows:
- We develop a STAR-RIS-assisted coal mine communication architecture with multiple BS-side MAs, enabling simultaneous shaping of the direct BS-to-device links and BS-to-STAR-RIS cascaded links.
- We introduce a hardware-realistic MA feasibility model in which the BS panel is partitioned into non-overlapping irregular subregions by mechanical and RF structures; this converts BS-side MA positioning into an assignment-coupled MINLP.
- We propose a penalty-based MINLP solver integrated into a BCD pipeline, including Hungarian-based assignment initialization, cross-region jump operations, and collision-aware correction.
- We validate the method under coal mine channel settings and practical impairments, showing consistent gains in throughput and power efficiency against multiple baselines.
For clarity, the main mathematical symbols used throughout this paper are summarized in Table 2.
Table 2.
Summary of main mathematical symbols.
2. System Model and Problem Formulation
2.1. System Model
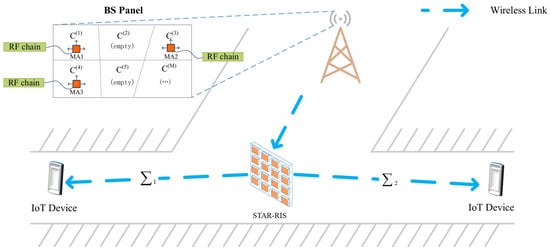
As depicted in Figure 1, this work considers an underground coal mine wireless communication scenario incorporating a STAR-RIS and a MA-equipped BS deployed jointly [16,25,26]. Specifically, the BS is mounted with M MAs arranged on a planar panel, while a STAR-RIS is positioned at a roadway junction underground, serving K IoT devices in the coal mine, each of which carries a single antenna fixed at a predetermined location [39,40]. These IoT devices are affixed to ore-transport vehicles traveling through underground tunnels and are fitted with wireless sensors for monitoring environmental conditions in the surrounding area [41]. The BS panel accommodates an uniform planar array (UPA) of MAs, where each element can be freely repositioned to enhance channel quality.The STAR-RIS adopts an UPA structure, and the total number of served devices is assumed not to surpass the number of antennas at the BS.
Figure 1.
STAR-RIS-aided wireless communication systems in coal mines. Solid arrows indicate wireless links between the BS, STAR-RIS, and IoT devices; dashed lines denote the tunnel boundaries.
In practice, the BS antenna panel is shared among all M MA elements. The panel accommodates multiple co-located hardware components—including mechanical support structures and RF feed lines, which physically divide the entire panel surface into S non-overlapping irregular subregions, where . All M MAs share the same set of subregions, and each subregion can accommodate at most one MA at any given time, which reflects the modular rail design adopted to prevent mechanical collisions among antenna elements. The shared feasible region of the BS antenna panel is modeled as:
where each subregion is an irregular quadrilateral defined by a set of linear inequality constraints:
where each subregion is a convex irregular quadrilateral defined by four linear inequality constraints, and are the constraint matrix and vector, respectively. In practice, the subregion geometry is determined at the BS panel design stage from the CAD layout of mechanical support structures and RF feed lines, whose positions are known a priori. Each subregion is modeled as a convex irregular quadrilateral with minimum size , constrained by the antenna aperture and actuator clearance. The constraint matrices and are pre-computed offline and remain fixed during operation. The subregions are mutually exclusive:
reflecting the physical separation among modular rail sections on the BS panel. Each MA m is assigned to exactly one subregion, and no two MAs share the same subregion. This one-to-one assignment is captured by a binary variable , where indicates that MA m is assigned to subregion . The assignment satisfies
Together, these constraints define a partial assignment problem over the binary matrix .
To describe the position of the m-th MA, a three-dimensional local coordinate system is established at the BS. Given the assignment , the position of MA m is constrained within subregion :
The collective position vector of all M MAs is defined as .
Note that since each subregion hosts at most one MA and the subregions are disjoint, the inter-antenna separation constraint is automatically satisfied for MAs assigned to different subregions, provided that does not exceed the minimum gap between any two subregions. For MAs within the same subregion, no collision is possible. Hence, the one-to-one assignment implicitly enforces collision avoidance, eliminating the need for a separate distance constraint.
Note also that the conventional rectangular cuboid model corresponds to the degenerate case of with a single box-constrained region, and is thus subsumed as a special instance of the proposed shared irregular partitioning model.
Due to the challenging conditions in underground environments—including intense mechanical vibrations, constrained physical space, and limited battery capacity—each IoT device is outfitted with a single antenna that remains fixed in place throughout operation. The position of the antenna on the k-th device is expressed in local coordinates as , where . Each device maintains its own independent local coordinate frame, with serving as the origin for the k-th device.
Furthermore, the placement of each MA on the BS panel is treated as an optimization variable , constrained to lie within its allocated subregion as specified in (6). The STAR-RIS employs an energy splitting (ES) strategy, under which the coefficient matrix takes the form for , capturing both transmission and reflection responses. The individual coefficients are expressed as and , where is the amplitude scaling factor governing the energy distribution between transmission and reflection, and denotes the phase shift applied by the n-th STAR-RIS element [42].
2.2. Propagation Channel Model
The adopted field response channel model captures multipath propagation characteristics through amplitude, phase, AoD, and AoA parameters, which collectively enable spatial channel manipulation across the MA deployment region [43]. Throughout this work, a narrowband slow-fading assumption is adopted, and channel variations are modeled using a quasi-static block fading framework [44]. For each device, the corresponding channel to the BS depends jointly on the surrounding propagation conditions and the current positions of the BS-side MAs .
2.2.1. BS-to-STAR-RIS Channel
We focus on the link connecting the BS-side UPA to the UPA deployed at the STAR-RIS.
Given that the BS antennas are repositionable, the resulting channel matrix linking the BS to the STAR-RIS is inherently dependent on the MA position vector . In what follows, refers to the carrier wavelength, and are the elevation and azimuth angles of the BS transmission, and , denote the inter-element spacings along the x and y axes at the BS, respectively.
Coal Mine Path Loss Model: Within underground coal mine tunnels, the large-scale fading coefficient is modeled through a log-distance relationship fitted to empirical field measurements [45]:
where is the path loss exponent for coal mine tunnels, dB/m accounts for coal dust and humidity attenuation, m is the reference distance, is the path loss at , and with dB models shadow fading.
To simplify the subsequent expressions, two formulas are defined as
and
These formulas concisely characterize the phase relationship related to the spacing, angle, and wavelength for the BS array response vector [46]. Since the MA positions are now optimizable variables, the transmit field response vector of the BS for the m-th MA is position-dependent:
where denotes the propagation distance difference between MA position and the BS coordinate origin, with virtual departure angles defined as in the original field response model [47].
Based on the above definitions, the array response vector of the BS for MA position is
where , , .
Similarly, let denote the elevation angle of the signal transmitted by the STAR-RIS; is the azimuth angle, and are the spacings of the STAR-RIS in the directions, respectively. Two formulas are introduced:
and
Based on the above definitions, the array response vector of the STAR-RIS is
where , , .
The transmit-field response matrix of the BS aggregates the position-dependent responses of all M MAs. This matrix is expressed as
Unlike the conventional fixed-antenna case where is a constant matrix, now varies with the MA positions and serves as an additional degree of freedom for channel optimization.
Therefore, the channel from the BS to the STAR-RIS as a function of MA positions is expressed as
where now explicitly depends on the BS-side MA position vector , and is computed using (7) with the BS-to-RIS distance. As the MA positions are optimized, is updated accordingly, providing an additional spatial degree of freedom beyond the STAR-RIS phase optimization.
2.2.2. BS-to-Device Channel
Consider the direct communication link from the BS to the k-th underground IoT device, denoted by . Since the device antenna is fixed, the receive-field response vector is a constant vector determined by the fixed device antenna position :
where is the propagation distance difference of the j-th receive path at the fixed device antenna position .
The virtual departure and arrival angles are defined as
where and .
The direct channel from the BS to the k-th device is expressed as a function of the BS-side MA positions:
where is defined in (15), is the path response matrix describing the coupling between transmit and receive paths, and is the constant receive field response vector of the fixed device antenna. The large-scale fading coefficient is computed using (7). In contrast to the original formulation where is constant and is position-dependent, the roles are reversed: is fixed while varies with the optimizable BS-side MA positions.
2.2.3. STAR-RIS-to-Device Channel
Since the device antenna is fixed, the channel from the STAR-RIS to the k-th underground IoT device becomes a constant vector independent of any optimization variable:
where is the constant receive field response vector at the fixed device antenna position :
The transmit field response vector of the STAR-RIS remains
where for and .
The transmit-field response matrix of the STAR-RIS is defined as
where . Both and are constant matrices/vectors since neither the STAR-RIS element positions nor the device antenna positions change during optimization.
2.2.4. Channel State Information Acquisition
Accurate channel state information (CSI) is essential for the proposed joint optimization framework. For the BS-side MA-aided system, the channel estimation is performed with the MAs fixed at their current positions during the pilot transmission phase. Upon completing each estimation, the MA positions are updated by the optimization algorithm, and re-estimation is triggered if the position change exceeds a predefined threshold. For STAR-RIS-aided systems, we adopt the time-division pilot-based channel estimation protocol [48].
Estimation Protocol: The STAR-RIS alternates between two operating modes during the pilot transmission phase:
- Transmission Mode: Set and for all . Devices on the transmit side estimate the cascaded channel .
- Reflection Mode: Set and for all . Devices on the reflective side estimate the cascaded channel .
The direct channel is estimated with STAR-RIS elements deactivated ().
Overhead Analysis: The total pilot overhead is symbols per coherence block. For typical coal mine parameters with and , the pilot overhead is symbols. Given the coherence time ms [45] and symbol rate MHz:
which is negligible in practice.
Estimation Accuracy: To account for the practical limitation of perfect CSI, we adopt an imperfect CSI model throughout this work. The channel estimation achieves a normalized mean square error (NMSE) of approximately dB under typical coal mine SNR conditions [49]. The estimated effective channel is modeled as
where with dB represents the estimation error.
2.3. Communication Model
The transmit signal vector at the BS is constructed as
where denotes the unit-power data symbol destined for the k-th IoT device underground, and is the associated beamforming vector allocated by the BS for device k.
Operating under the ES mode, the STAR-RIS enables each reconfigurable element to handle both transmission and reflection of incoming electromagnetic signals concurrently. The K devices are partitioned into two groups: devices reside on the T-side, while devices occupy the R-side, satisfying with .
As introduced in Section 2.1, the coefficient matrix applicable to device k is selected according to its spatial side:
The observation at the k-th underground IoT device takes the form
where is the additive white Gaussian noise term, and is the composite channel vector aggregating contributions from both the direct BS-to-device path and the STAR-RIS-assisted path:
In the above, and vary with MA positions as formulated in (20) and the BS-to-STAR-RIS channel expression, whereas remains constant owing to the fixed device antenna. Consequently, the MA position vector exerts influence over both propagation paths simultaneously, yielding a more flexible optimization space relative to the receiver-side MA case.
Expanding the received signal yields
in which the three terms correspond to the desired signal component, the co-channel interference from other devices, and the background noise, respectively.
The resulting SINR at the k-th device is expressed as
Accordingly, the achievable throughput for device k is given by
where B denotes the system bandwidth. The explicit dependence on reflects how BS-side MA repositioning jointly shapes both propagation paths, enabling transmit-side spatial degrees of freedom to be exploited for interference mitigation in underground coal mine environments.
2.4. Problem Formulation
Under the communication model established above, our objective is to jointly optimize the active beamforming vectors at the BS, the passive beamforming coefficients of the STAR-RIS, the positions of the BS-side MAs, and the subregion assignment of each MA to maximize the system sum-rate.
The joint optimization problem is formulated as
where and represent the minimum rate requirement and maximum transmit power, respectively. Constraint (34d) ensures energy conservation at each STAR-RIS element. Constraint (34g) confines each MA within its assigned subregion of the BS panel (see Section 2.1). Constraints (34h) and (34i) together enforce a one-to-one assignment: each MA occupies exactly one subregion and each subregion hosts at most one MA, implicitly preventing mechanical collisions. Constraint (34j) enforces integrality, and constraint (34k) ensures assignment feasibility via .
The combination of constraints (34h)–(34j) constitutes a partial assignment problem over the binary decision matrix . The introduction of this binary assignment matrix elevates the antenna positioning subproblem from a continuous nonlinear program (NLP) to a mixed-integer nonlinear program (MINLP) [50], which is NP-hard in general. This fundamentally invalidates the simple box-projection operator used in conventional MA positioning optimization, necessitating a specialized solution approach. Problem (34) is further non-convex due to the coupled optimization variables and fractional SINR structure. We develop a block coordinate descent (BCD) algorithm with a penalty-based MINLP solver incorporating a joint assignment-positioning optimization strategy to obtain a high-quality suboptimal solution.
3. Optimization Algorithm
Problem (34) is non-convex with coupled variables; directly obtaining the global optimum is intractable. To address this challenge, we propose a block coordinate descent (BCD) algorithm that alternately optimizes each block of variables while keeping the others fixed.
3.1. BCD Framework
The coal mine environmental attenuation in (7) directly affects the large-scale fading coefficients in the effective channel (24). Our joint optimization automatically adapts to harsh underground conditions through three mechanisms: beamforming compensates power allocation for attenuated devices, STAR-RIS provides dual-path diversity by adjusting energy splitting ratios, and MA positions dynamically avoid deep fading zones via gradient-based repositioning. The BCD framework alternately optimizes three variable blocks—beamforming , STAR-RIS coefficients , and MA positions —while keeping the remaining blocks fixed, and terminates when the sum-rate increment falls below threshold .
3.2. BS Beamforming Optimization
With fixed STAR-RIS coefficients and BS-side MA positions with assignment , the beamforming (BF) optimization subproblem becomes
where is given by the SINR expression with the effective channel:
where and are functions of the BS-side MA position vector as defined in (20) and the BS-to-STAR-RIS channel equation, respectively, while is the constant STAR-RIS-to-device channel vector.
3.2.1. SDR-Based Solution for Beamforming
To handle the non-convex fractional objective, we apply semidefinite relaxation (SDR). We define the beamforming matrix and the effective channel matrix . The problem becomes
Rank-1 Recovery: After solving the SDP, if the optimal is naturally rank-1, the beamforming vector is directly extracted as via EVD. If the rank exceeds one, Gaussian randomization is applied: we generate L candidate vectors , , and select the one that best satisfies the original constraints.
3.2.2. SCA
The logarithmic rate constraints remain non-convex. We employ successive convex approximation (SCA) by introducing auxiliary optimization variables , and using a first-order Taylor expansion around the current operating point.
At iteration n, we apply first-order Taylor expansion around the current point :
where
After relaxing the rank-1 constraints, the problem becomes a standard semidefinite programming (SDP) that can be solved efficiently using interior-point methods. The proposed beamforming optimization algorithm is summarized in Algorithm 1.
| Algorithm 1 SCA-Based Beamforming Optimization |
| Require: Effective channels , power budget Ensure: Optimized beamforming vectors
|
3.3. STAR-RIS Phase Shift Optimization
With fixed beamforming vectors and BS-side MA positions , we optimize the STAR-RIS phase shift coefficients. The subproblem becomes
3.3.1. Problem Reformulation
We define the transmission and reflection coefficient vectors as
The effective channel for device k can be written as
To facilitate optimization, we define the augmented coefficient vector:
and the corresponding signal vector:
The received signal power at device k becomes
where .
3.3.2. SDR-Based Solution
We apply semidefinite relaxation by defining and relaxing the rank-1 constraint. The problem becomes
where denotes the -th element of matrix .
Rank-1 Recovery: Similarly, if the optimal has rank greater than one after solving (48), Gaussian randomization is applied to recover a feasible rank-1 solution. In practice, the SDR solutions for both subproblems are observed to be rank-1 in over 95% of Monte Carlo trials under the simulation settings of Section 4.
3.3.3. Penalty-Based Rank Relaxation
The rank-1 constraint is handled using a penalty method. We replace it with
Since this constraint is still non-convex, we use first-order Taylor approximation around the current point :
where is the eigenvector corresponding to the largest eigenvalue of .
3.3.4. Penalized Optimization Problem
We define the penalty function as
The penalized optimization problem becomes
where is the penalty parameter. The proposed STAR-RIS phase shift optimization algorithm is summarized in Algorithm 2.
| Algorithm 2 STAR-RIS Phase Shift Optimization |
| Require: Beamforming vectors , MA positions Ensure: Optimized STAR-RIS coefficients ,
|
3.3.5. Computational Complexity
The computational complexity of Algorithm 2 is per iteration, where N is the number of STAR-RIS elements and is the desired accuracy. The penalty method typically converges within 10–20 iterations for practical problems.
3.4. BS-Side MA Position Optimization
With fixed beamforming vectors and STAR-RIS coefficients , we jointly optimize the BS-side MA positions and the subregion assignment matrix to further improve the system performance. The position optimization subproblem is
where is the 3D position of the m-th BS-side MA, and denotes the s-th shared convex subregion of the BS antenna panel as defined in Section 2.1. Constraint (53d) ensures each MA is assigned to exactly one subregion, constraint (53e) enforces the one-to-one assignment rule that each subregion hosts at most one MA, thereby implicitly preventing mechanical collision, and constraint (53g) guarantees assignment feasibility.
3.4.1. MINLP Reformulation via Penalty Relaxation
The binary assignment matrix in constraints (53d)–(53f) renders subproblem (53) a mixed-integer nonlinear program (MINLP), which is NP-hard in general. To handle this, we employ a penalty-based continuous relaxation that softens the binary and assignment constraints into continuous ones while progressively enforcing integrality and the one-to-one assignment structure.
Specifically, we relax to and append two penalty terms. The first enforces binary values:
where is the binary penalty weight. The second enforces the column constraint (53e) that each subregion hosts at most one MA:
where is the column assignment penalty weight. Note that if and only if all , and if and only if constraint (53e) is satisfied. Increasing and progressively drives the solution toward a valid one-to-one assignment.
Define the rate violation for device k as
The penalized augmented objective function becomes
where is the concatenated BS-side MA position vector, collects all , and is the rate violation penalty. The four terms respectively maximize the sum rate, enforce minimum rate constraints, drive assignment variables toward binary values, and enforce the one-to-one subregion assignment.
3.4.2. Joint Assignment Initialization via Hungarian Algorithm
A good initialization is critical for avoiding poor local optima and ensuring a feasible one-to-one assignment from the start. Unlike the independent per-MA region selection used in unconstrained settings, the column constraint (53e) requires a coordinated initialization that assigns all M MAs to distinct subregions simultaneously.
We first construct a channel quality matrix , where the -th entry represents the average channel quality of MA m in subregion :
where is the i-th sampled position within the shared subregion , and denotes the instantaneous SINR evaluated at a candidate position.
Given the quality matrix , the initial one-to-one assignment is obtained by solving the linear assignment problem:
which is efficiently solved by the Hungarian algorithm [51] in time. Each MA m is then initialized at the centroid of its assigned subregion , where .
The Hungarian-based initialization provides a feasible starting point that satisfies all assignment constraints (53d)–(53f), ensuring the algorithm begins from a valid configuration rather than an arbitrary or infeasible point. The Hungarian algorithm is preferred over random initialization for two reasons. First, it solves the linear assignment problem (59) to global optimality in time [51], guaranteeing that the initial subregion assignment maximizes the sum channel quality rather than relying on chance. Second, it always produces a feasible assignment satisfying constraints (34h) and (34i), ensuring the algorithm starts from a valid configuration without requiring a feasibility-restoration step.
3.4.3. Projected Gradient Ascent Within Assigned Subregion
The gradient of with respect to the BS-side MA position vector is approximated via the finite difference method. For the i-th component:
where is a small perturbation step and is the i-th unit vector. The gradient ascent update is then given by
where is the gradient ascent step size, which is distinct from the subregion assignment variables .
To maintain feasibility, the tentative position of MA m is projected onto its currently assigned subregion , which forms a convex polytope:
which constitutes a standard convex quadratic program solvable efficiently via CVX [52]. This formulation supersedes the simple coordinate-wise clipping employed in conventional box-constrained MA systems. Since the one-to-one assignment (53e) inherently separates antennas across disjoint subregions, no additional collision-avoidance step is required after projection, simplifying implementation.
3.4.4. Global Reassignment-Based Jump Mechanism
A fundamental challenge in optimizing over non-contiguous shared feasible regions is that gradient-based methods may converge to a locally optimal assignment while a globally better assignment exists. Unlike the unconstrained case where each MA independently selects its subregion, the column constraint (53e) couples the assignment decisions of all M MAs: relocating one MA to a different subregion may require simultaneously adjusting other MAs to maintain the one-to-one assignment. To address this, we introduce a global reassignment mechanism that periodically re-solves the assignment problem over the current channel quality estimates.
Every iterations, the global reassignment proceeds as follows:
- Evaluate current quality: Compute the current augmented objective under the existing assignment .
- Update quality matrix: Re-evaluate the channel quality matrix based on the current MA positions, where the -th entry is computed by sampling positions within shared subregion :
- Re-solve assignment: Find the new optimal one-to-one assignment via the Hungarian algorithm [51]:
- Accept if improving: Evaluate under with each MA initialized at the centroid of its newly assigned subregion. If , accept the new assignment:and reset the step size to facilitate re-exploration under the new assignment.
The global reassignment is accepted only when it strictly improves , ensuring monotonic non-decrease in the augmented objective across jump events. Since the Hungarian algorithm solves the linear assignment problem optimally in time and in our setting, the overhead of each jump event is negligible compared to the gradient computation cost.
Between jump events, the assignment variables are updated via projected gradient ascent:
followed by projection onto the relaxed assignment polytope via Sinkhorn iterations [53], which efficiently enforce both row and column constraints simultaneously. Here, is the step size for .
The complete BS-side MA position optimization procedure is summarized in Algorithm 3.
3.4.5. Convergence and Complexity Analysis
Algorithm 3 converges under the following conditions:
- The objective function is locally Lipschitz continuous, which holds since is continuously differentiable with respect to within each convex subregion;
- The step size satisfies where L is the Lipschitz constant, enforced via backtracking line search;
- The constraint sets are convex and compact, ensuring the existence of the projection (62);
- The cross-region jump in is accepted only when improves, guaranteeing monotonic non-decrease across jump events.
Within each subregion, the projected gradient iterates converge to a stationary point of restricted to that subregion. The cross-region jump mechanism ensures that the algorithm does not terminate at a suboptimal subregion, yielding a solution that is locally optimal across all subregions.
The computational complexity per iteration is for channel evaluation and for the cross-region jump evaluation (triggered every iterations). The dominant cost is the channel re-evaluation for gradient computation, which is the same order as the original device-side MA algorithm.
| Algorithm 3 Penalty-Based BS-side MA Joint Assignment and Position Optimization |
| Require: Beamforming vectors , STAR-RIS coefficients , shaped feasible subregions with Ensure: Optimized BS-side MA positions and assignment matrix
|
3.4.6. Practical Implementation Considerations
- Step size adaptation: Use backtracking line search to ensure sufficient increase in ;
- Penalty parameter tuning: Start with small and , increase by factor per iteration until binary convergence;
- Gradient approximation: The finite difference step balances numerical precision and computational cost;
- Jump frequency: Set –10 to balance exploration and exploitation; too frequent jumps slow convergence, while too infrequent jumps risk subregion trapping;
- Subregion sampling: Use –20 samples per subregion for initialization quality assessment.
3.5. Overall BCD Algorithm
The proposed joint optimization algorithm based on BCD is summarized in Algorithm 4. In each iteration, we first fix the STAR-RIS phase shifts and MA positions to optimize the BS beamforming vectors using Algorithm 1. Then, we fix the BS beamforming and MA positions to optimize the STAR-RIS phase shifts using Algorithm 2. Finally, we fix the BS beamforming and STAR-RIS phase shifts to optimize the MA positions using Algorithm 3. The iterations continue until the change in sum rate is less than a preset threshold .
| Algorithm 4 Overall BCD Algorithm |
| Require: Channel matrices, system parameters, feasible subregions Ensure: Optimized , ,
|
Complexity of Algorithm 4. Each outer BCD iteration invokes three sub-algorithms sequentially. Algorithm 1 (SCA-based beamforming) requires solving an SDP of size , with a per-iteration complexity of . Algorithm 2 (STAR-RIS optimization) solves an SDP of size , with a per-iteration complexity of . Algorithm 3 (MA position optimization) has a per-iteration complexity of for channel evaluation and for Hungarian reassignment. Therefore, the overall per-iteration complexity of Algorithm 4 is
where , , and denote the number of inner iterations for Algorithms 1, 2, and 3, respectively. For the default parameters , , , the dominant cost per BCD iteration is , which is computationally tractable.
3.6. Convergence Analysis
We discuss the convergence behavior of the proposed BCD algorithm (Algorithm 4). The analysis covers the monotonicity and limit-point properties of the iterates.
Proposition 1
(Convergence of Algorithm 4). Let denote the sequence generated by Algorithm 4. Then:
- (a)
- The objective function is monotonically non-decreasing:
- (b)
- Every limit point of the sequence satisfies the Karush–Kuhn–Tucker (KKT) stationarity conditions of the penalty-relaxed continuous problem. Exact stationarity of the original MINLP is not claimed, as the MA subproblem involves a penalty-based relaxation and discrete reassignment steps that fall outside standard BCD convergence guarantees.
We prove each part separately.
Part (a)—Monotonicity: The BCD framework optimizes each block of variables while fixing others. At iteration t:
Combining inequalities (69)–(71) yields part (a).
Part (b)—Convergence to Stationary Point: We invoke the general convergence result for BCD methods [40]. The following conditions are satisfied:
Condition 1 (Objective Boundedness): The sum rate is bounded above by the Shannon capacity limit with perfect CSI:
Condition 2 (Feasible Set Compactness): The feasible set is compact:
- (power constraint);
- (amplitude constraint);
- where is a bounded convex polytope;
- with (relaxed assignment).
Hence, is a closed and bounded subset of a finite-dimensional Euclidean space, thus compact by the Heine–Borel theorem.
Condition 3 (Subproblem Optimality): Algorithms 1 and 2 achieve -optimality of their respective convex relaxations via standard SCA/SDR convergence results. For Algorithm 3, the penalty-based continuous relaxation with Hungarian reassignment and cross-region jumps is designed to reduce the augmented objective at each step; however, the discrete reassignment component means that exact -optimality in the BCD sense holds only for the relaxed (penalty-continuous) subproblem, not for the original MINLP. Convergence of the overall sequence to a limit point of the penalty-relaxed problem follows from the monotonicity established in Part (a) and the boundedness of the feasible set; stationarity of the limit point with respect to the original MINLP is not guaranteed in general.
Remark 1
(KKT Conditions). At convergence, the solution satisfies the following necessary KKT conditions:
Stationarity:
Primal Feasibility:
Dual Feasibility:
Complementary Slackness:
where is the Lagrangian of Problem (34).
4. Simulation Results and Analysis
4.1. Simulation Parameter Settings
To evaluate the performance of the proposed joint STAR-RIS and MA optimization scheme, we conduct extensive simulations in a typical underground coal mine communication scenario. All simulations are implemented in MATLAB R2023b and Python 3.9; convex subproblems are solved via CVX [52]. Each plotted data point is averaged over 200 independent Monte Carlo trials, with device locations and channel realizations drawn independently in each trial and a fixed random seed used for MA subregion initialization to ensure reproducibility.
4.1.1. System Configuration
(unless otherwise specified) underground IoT devices are randomly distributed in a rectangular tunnel located underground within the region to [54]. The BS is located on the ground at and equipped with MAs configured as a UPA on the BS antenna panel. In practice, the panel is physically divided into non-overlapping irregular subregions by mechanical support structures and RF feed lines, where each subregion spans approximately . The MAs are assigned to 8 of the 10 available subregions via the Hungarian algorithm, with the remaining two subregions left unoccupied to provide assignment flexibility. STAR-RIS with elements ( UPA) is deployed at the intersection of two tunnels at reference position . Each underground IoT device is equipped with a single fixed-position antenna, which is practically justified by the harsh underground conditions including severe vibration, battery power constraints, and limited device space.
The key simulation parameters are justified as follows. Transmit power dBm and noise power dBm are consistent with typical BS deployments in underground IoT networks [5]. Path loss exponent and environmental attenuation dB/m are taken from empirical measurements in coal mine tunnels [48]. Carrier frequency GHz follows the ISM band standard for underground IoT [2]. Number of devices matches the number of BS antennas , satisfying the condition required for spatial multiplexing.
4.1.2. Channel Model
The wireless channels are characterized using the field response channel model [47]:
- Carrier frequency: GHz (wavelength m);
- Number of multipath components: paths per link;
- Fading model: Rayleigh fading for NLOS components with path loss following underground tunnel propagation characteristics.
The main system parameters are shown in Table 3. Unless otherwise specified, the transmit power of BS is set as dBm, and equal rate requirements Mbps.
Table 3.
Simulation parameter settings.
4.1.3. Baseline Schemes
To comprehensively evaluate the proposed approach, we compare with the following baseline schemes:
- 1.
- No Assistance: Direct BS-to-device communication without RIS or antenna mobility. Only BS beamforming is optimized using Algorithm 1.
- 2.
- Conventional RIS: Traditional reflection-only RIS with passive reflecting elements and fixed BS antennas. Joint optimization of BS beamforming and RIS phase shifts using SDR and SCA methods.
- 3.
- STAR-RIS + Fixed BS Antenna: STAR-RIS with simultaneous transmission and reflection capabilities, but with fixed BS antenna positions. Joint optimization of BS beamforming and STAR-RIS coefficients using Algorithms 1 and 2.
- 4.
- STAR-RIS + BS-MA (Regular Region): STAR-RIS combined with BS-side MAs, where the feasible moving region of each MA is modeled as a conventional continuous rectangular cuboid with the same total area as the proposed irregular partitioned regions. This baseline uses the same BCD framework but replaces the MINLP solver with standard projected gradient descent, serving as a direct comparison to evaluate the performance gain from irregular partitioning.
- 5.
- STAR-RIS + BS-MA (Greedy Assignment): STAR-RIS combined with BS-side MAs constrained to shared irregular partitioned subregions, but with subregion assignment determined by a greedy algorithm that sequentially assigns each MA to the highest-quality available subregion without global coordination, serving as a direct comparison to evaluate the benefit of the proposed Hungarian-based global assignment.
- 6.
- Proposed STAR-RIS + BS-MA (Irregular Partition): The proposed joint optimization scheme with BS-side MAs constrained to shared irregular partitioned subregions, solved using Algorithm 4 with the penalty-based MINLP solver and global reassignment mechanism.
4.2. Baseline Method Comparison
To validate the effectiveness of the proposed STAR-RIS and MA joint optimization scheme, we compare it against the baseline methods described in Section 4.1.3 under identical simulation conditions.
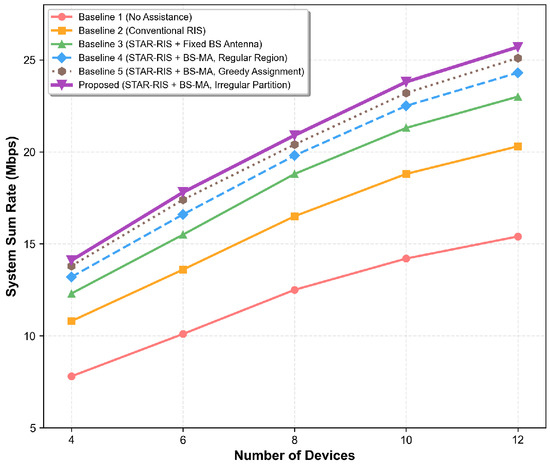
Figure 2 illustrates the performance comparison across different numbers of underground devices ranging from 4 to 12.
Figure 2.
Sum rate comparison versus number of devices for STAR-RIS elements and dBm.
Key findings from the baseline comparison:
- Across tested settings, the proposed design remains the dominant curve among all compared baselines;
- Compared to the no-assistance baseline, the proposed scheme delivers 66.7% improvement in sum rate at devices;
- STAR-RIS provides significant advantages over traditional RIS due to its full-space coverage capability;
- The greedy assignment baseline outperforms the regular-region baseline, confirming that the irregular subregion structure provides additional performance gains under practical hardware constraints; the proposed Hungarian-based initialization further improves over greedy assignment at , validating the benefit of globally optimal subregion coordination;
- The gain margin widens in denser user regimes, indicating stronger interference-management capability.
The baseline comparison validates that the proposed STAR-RIS and MA joint optimization delivers substantial and consistent performance improvements over existing approaches, making it well-suited for challenging coal mine communication environments.
4.3. Convergence Analysis, Ablation Study and Computational Complexity
To validate the proposed algorithm, we evaluate convergence behavior and computational efficiency under three progressive optimization configurations:
- BF only: Optimizes only BS beamforming using Algorithm 1;
- BF + STAR-RIS: Jointly optimizes beamforming and STAR-RIS coefficients using Algorithms 1 and 2;
- Proposed (BF + STAR-RIS + MA): Complete joint optimization using Algorithm 4.
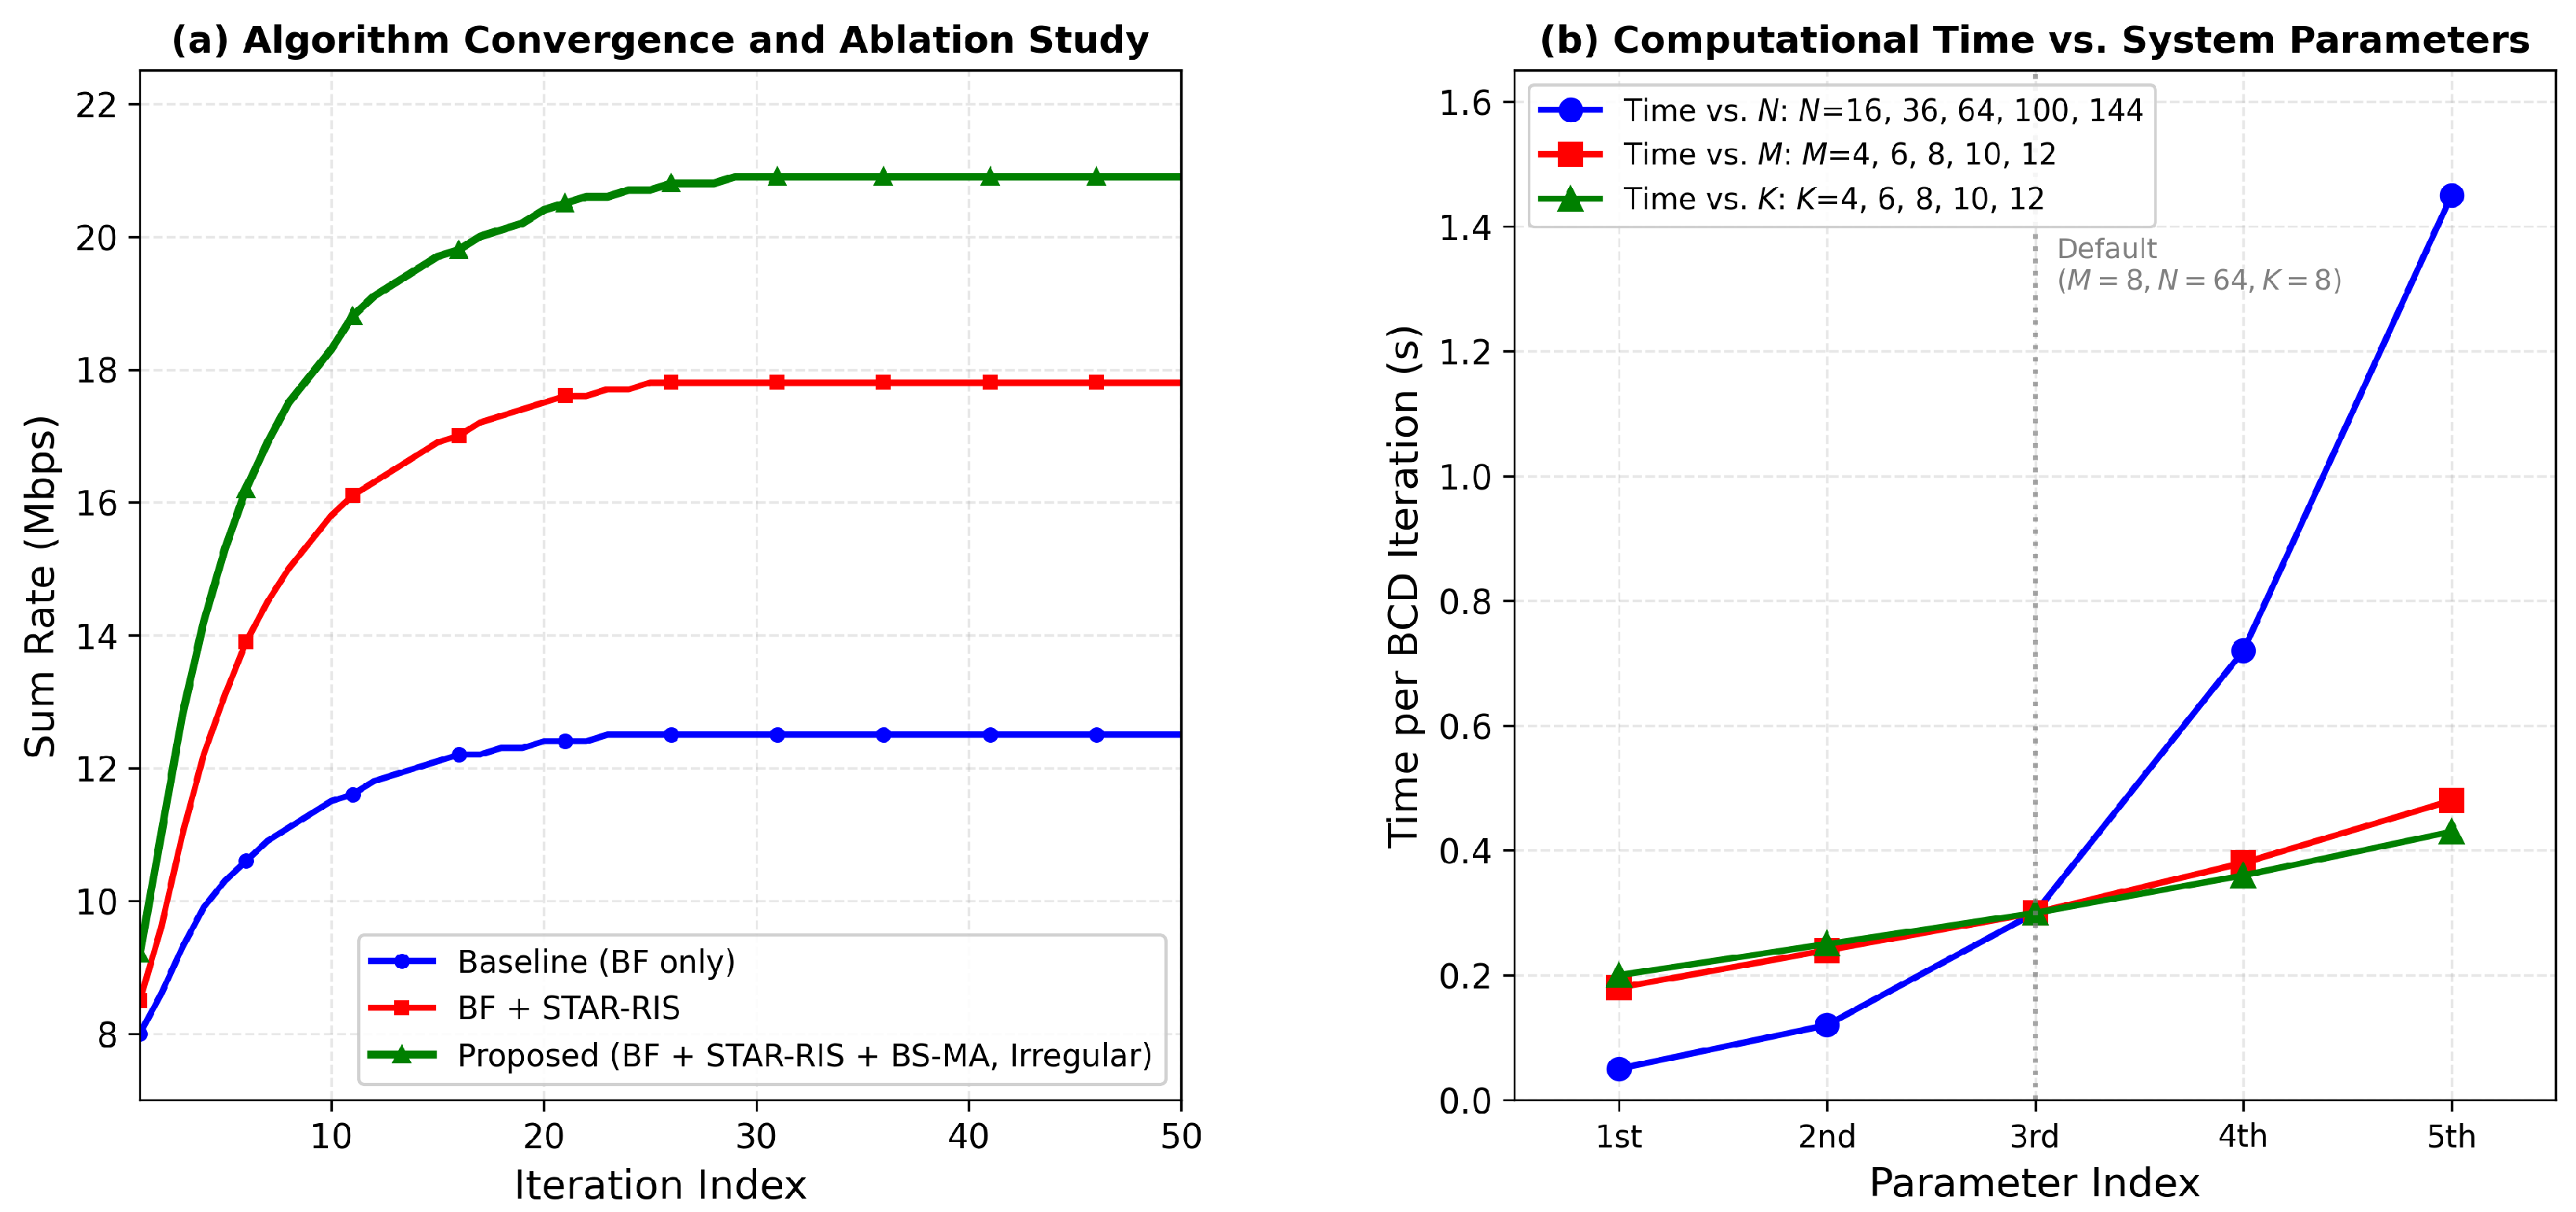
This comparison simultaneously serves as an ablation study isolating each component’s contribution. Figure 3 illustrates the convergence behavior and per-iteration computational time.
Figure 3.
(a) Algorithm convergence and ablation study for different optimization schemes with devices, showing 66.7% performance improvement of the proposed scheme over the BF-only baseline. (b) Computational time per BCD iteration versus system parameters N, M, and K, with all curves meeting at the default operating point (, , ) at 0.30 s/iteration.
Convergence: All three schemes reach steady-state within 40 iterations. The proposed scheme converges at a similar rate, confirming that Hungarian-based initialization provides a high-quality starting point.
Ablation Results:
- BF only: 12.5 Mbps (baseline);
- BF + STAR-RIS: 17.8 Mbps (+42.4%);
- Proposed: 20.9 Mbps (+66.7%).
STAR-RIS contributes 42.4% by enabling omnidirectional coverage; BS-side MA optimization adds a further 24.3% gain through spatial repositioning.
Computational Complexity: Figure 3b shows the per-iteration runtime versus N, M, and K. At the default setting (, , ), one BCD iteration takes approximately 0.30 s, consistent with the theoretical complexity , which dominates as N grows. The runtime remains below 1.5 s even at , confirming the practical feasibility of the proposed algorithm for underground coal mine deployments with quasi-static fading ( ms).
4.4. Transmit Power Efficiency Analysis
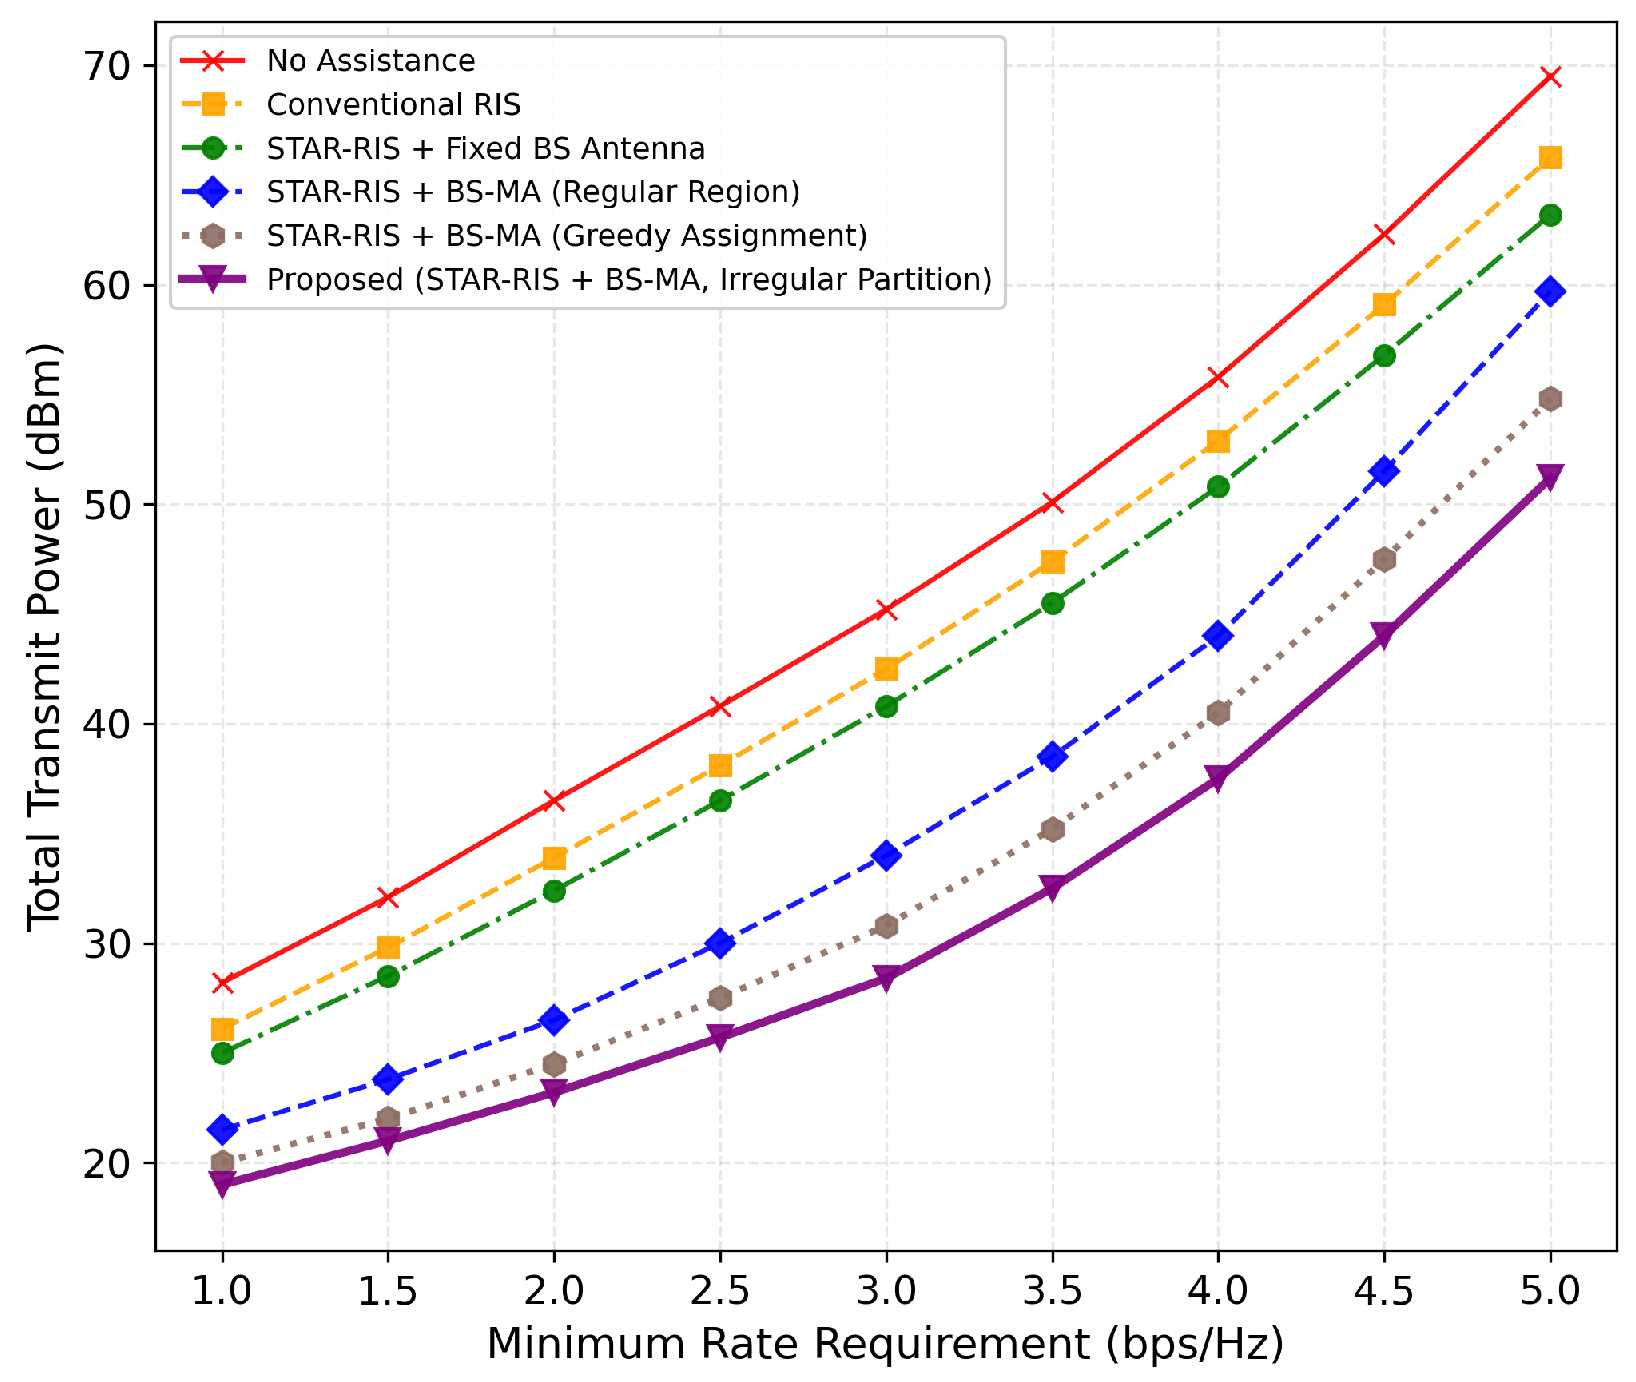
To justify the choice of Mbps and evaluate parameter sensitivity, we compare the proposed scheme against the baseline methods by examining the minimum required BS transmit power to satisfy varying per-device rate requirements from 1 to 5 Mbps with devices.
Figure 4 shows power requirements versus rate demands. The proposed scheme consistently achieves the lowest power consumption across all rate requirements, requiring only 28.4 dBm at 3 Mbps compared to 45.2 dBm for the no-assistance baseline, yielding a 16.8 dB power reduction. Compared to the regular-region baseline, which also employs BS-side MAs but without irregular partitioning, the proposed scheme saves an additional 5.6 dB at 3 Mbps, directly demonstrating the power efficiency benefit of the proposed irregular partitioning design. This 5.6 dB gain directly validates the practical value of hardware-aware irregular partitioning under real BS panel deployment constraints in coal mine environments. Furthermore, the greedy assignment baseline consistently requires more power than the proposed scheme, confirming that globally optimal Hungarian-based subregion coordination provides additional power savings beyond the structural benefit of irregular partitioning alone.
Figure 4.
Transmit power versus minimum rate requirement per device for devices and STAR-RIS elements.
The gain margin widens at higher rate targets. At 5 Mbps, the proposed scheme requires 18.3 dB less power than the no-assistance baseline, and approximately 8.5 dB less than the regular-region baseline. This growing gap confirms that as interference conditions intensify with higher rate demands, the spatial flexibility provided by irregular partitioned BS-side MAs—which simultaneously optimizes both the direct and STAR-RIS-assisted channels—becomes increasingly valuable for coal mine communication systems. The greedy assignment baseline falls between the regular-region baseline and the proposed scheme throughout, and this gap grows with rate demand, further confirming that global subregion coordination becomes increasingly critical under demanding rate requirements.
4.5. Parameter Sensitivity and Robustness Analysis
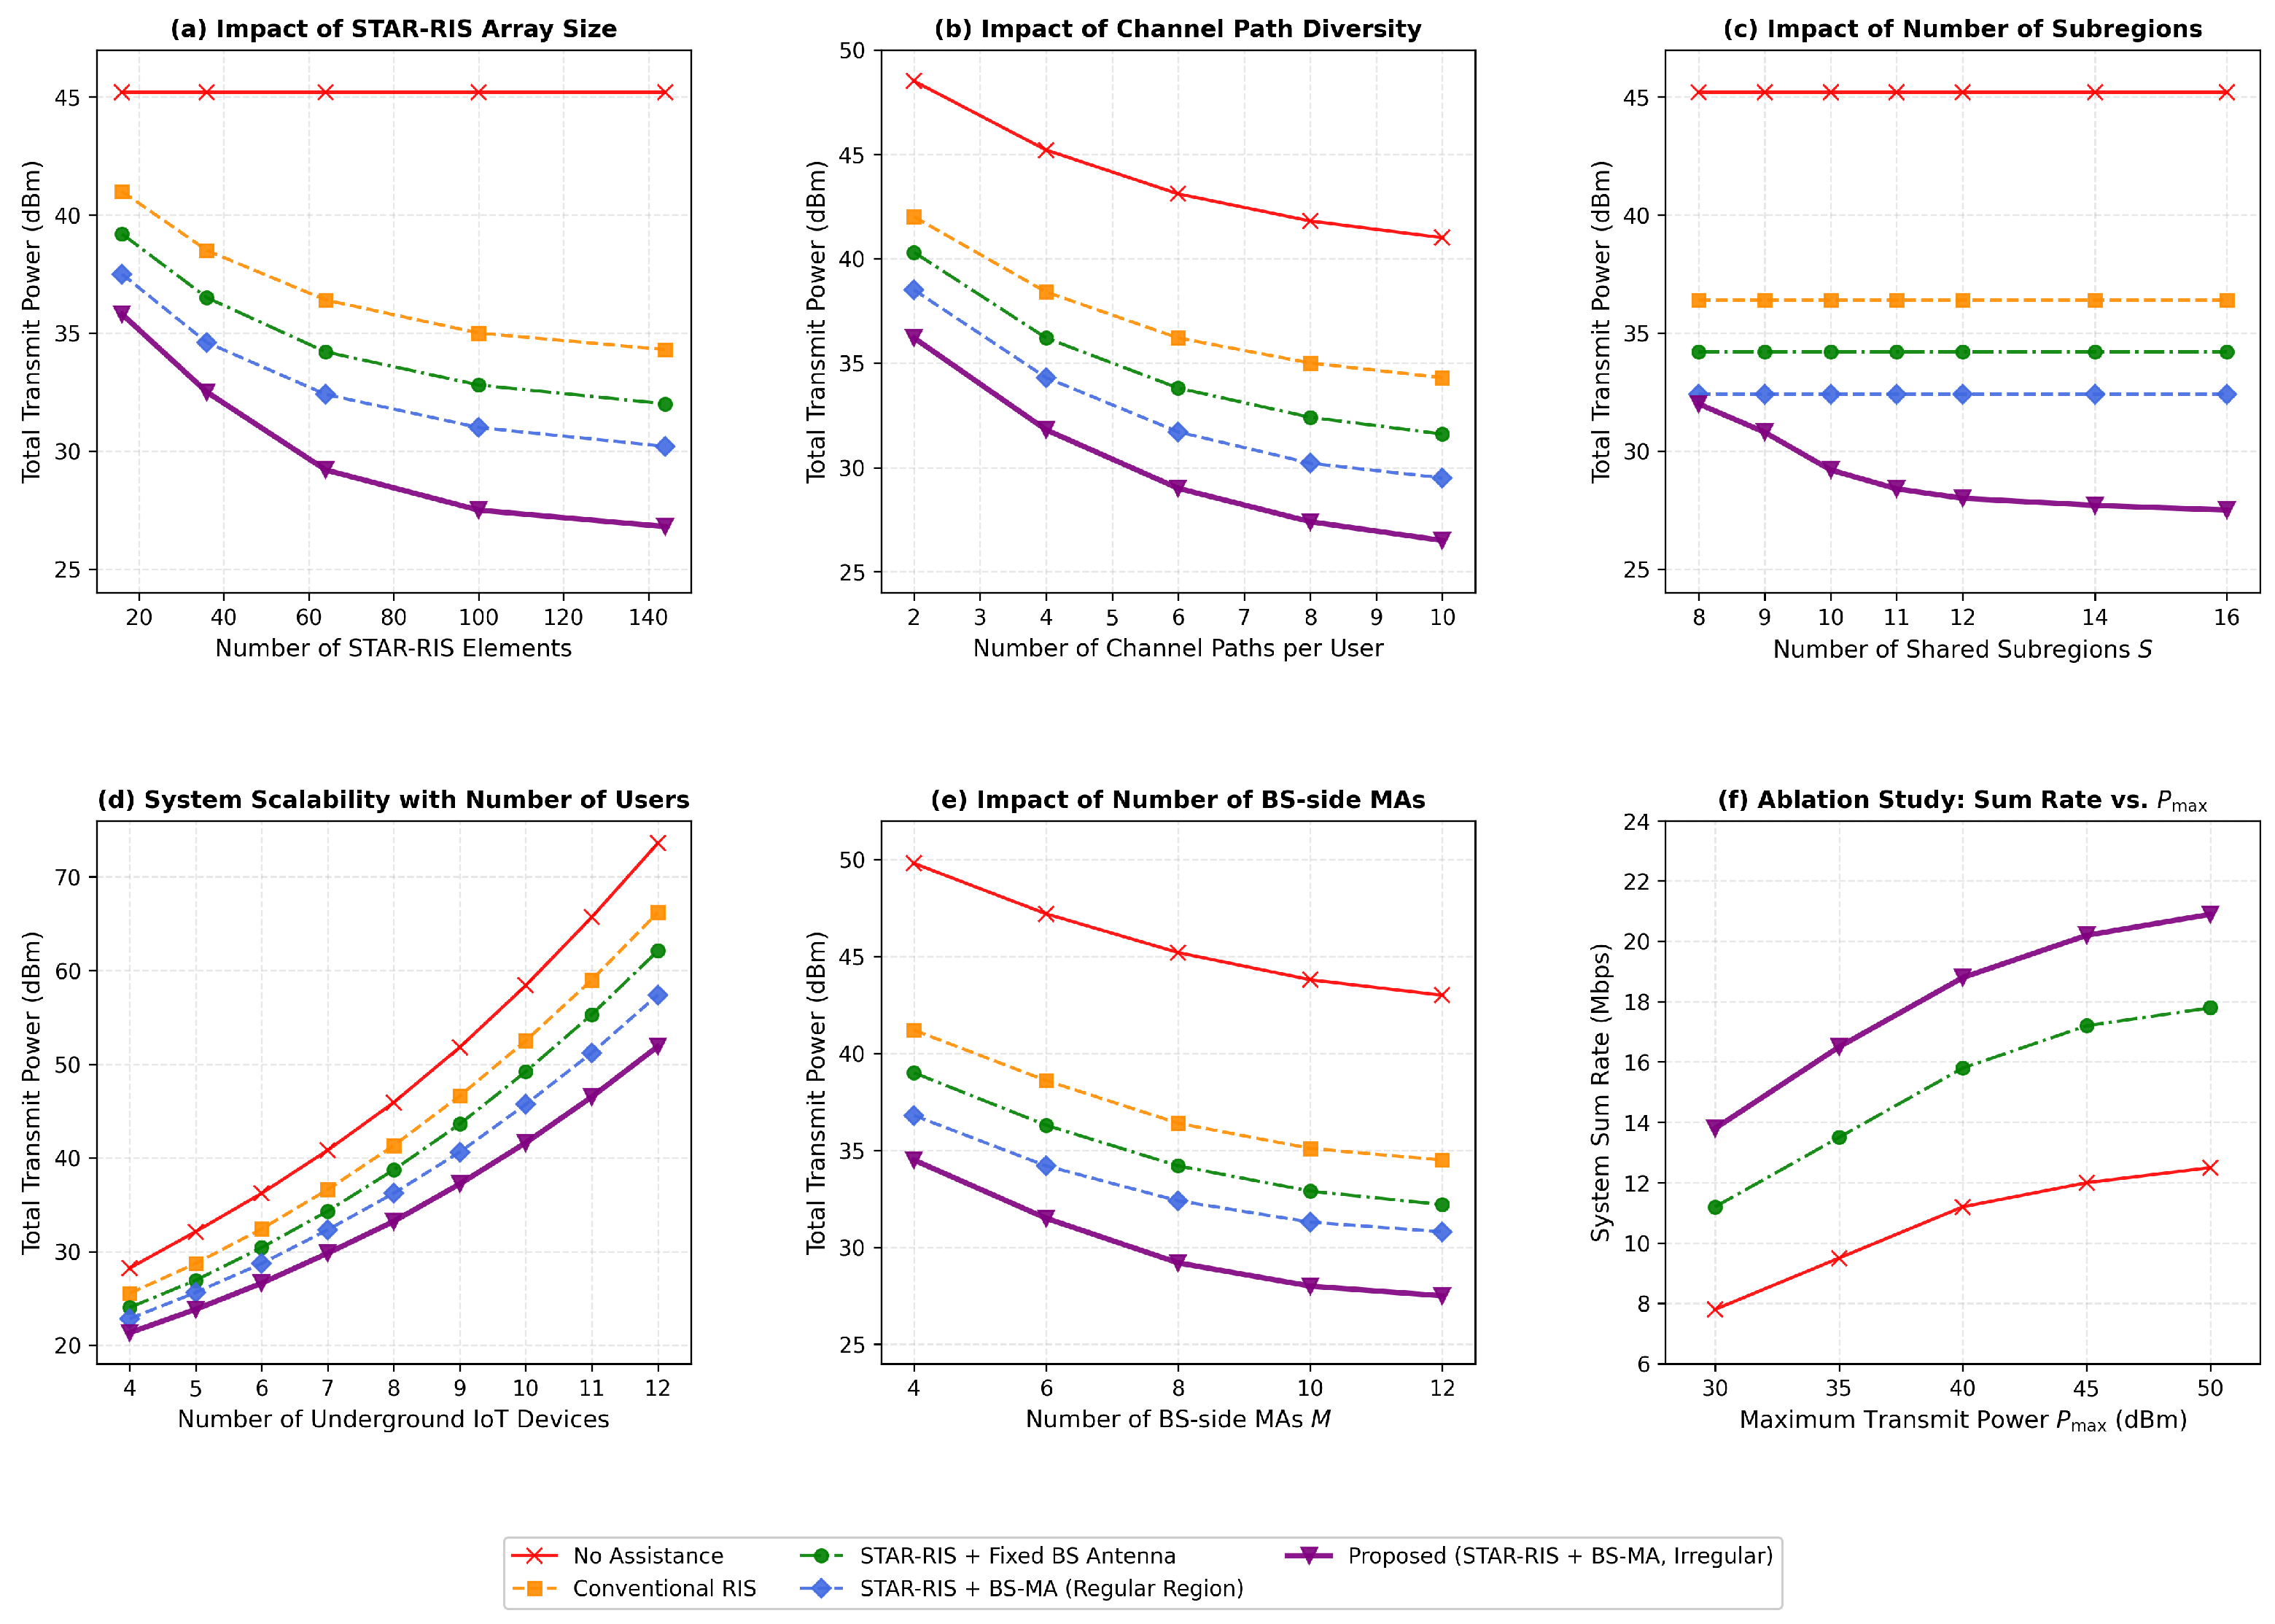
Figure 5 presents a comprehensive parameter sensitivity analysis with devices and dBm.
Figure 5.
Parameter sensitivity analysis with devices and dBm.
Array Size (Figure 5a): The proposed scheme benefits consistently from increasing the number of STAR-RIS elements, with performance saturating beyond 64 elements. The configuration provides the best cost–performance trade-off and is adopted as the default setting.
Channel Paths (Figure 5b): Performance saturates at –6 paths for all schemes, consistent with the limited scattering richness in underground coal mine tunnels. This validates the choice of in our channel model.
Subregion Configuration (Figure 5c): As S increases from 8 (the minimum feasible value equal to M) to 16, the proposed scheme achieves progressively lower transmit power, with performance saturating around . The gain arises from the Hungarian algorithm having more candidate subregions to form a better spatial assignment. The regular-region baseline and fixed-antenna schemes remain flat across all values of S, confirming that the performance gain is solely due to the irregular partitioning design. Based on this analysis, is selected as it provides near-optimal performance with moderate hardware complexity.
User Scalability (Figure 5d): The proposed scheme maintains the largest performance advantage as K increases from 4 to 12, demonstrating that BS-side MA with irregular partitioning scales well under increasing multi-user interference in coal mine environments.
Number of BS-side MAs (Figure 5e): As M increases from 4 to 12, the proposed scheme achieves progressively lower transmit power, with performance saturating around , validating the default choice of .
Ablation Study (Figure 5f): Adding STAR-RIS to BF-only yields a 42.4% sum-rate improvement, and further incorporating BS-side MA optimization contributes an additional 24.3% gain, confirming the individual contribution of each component.
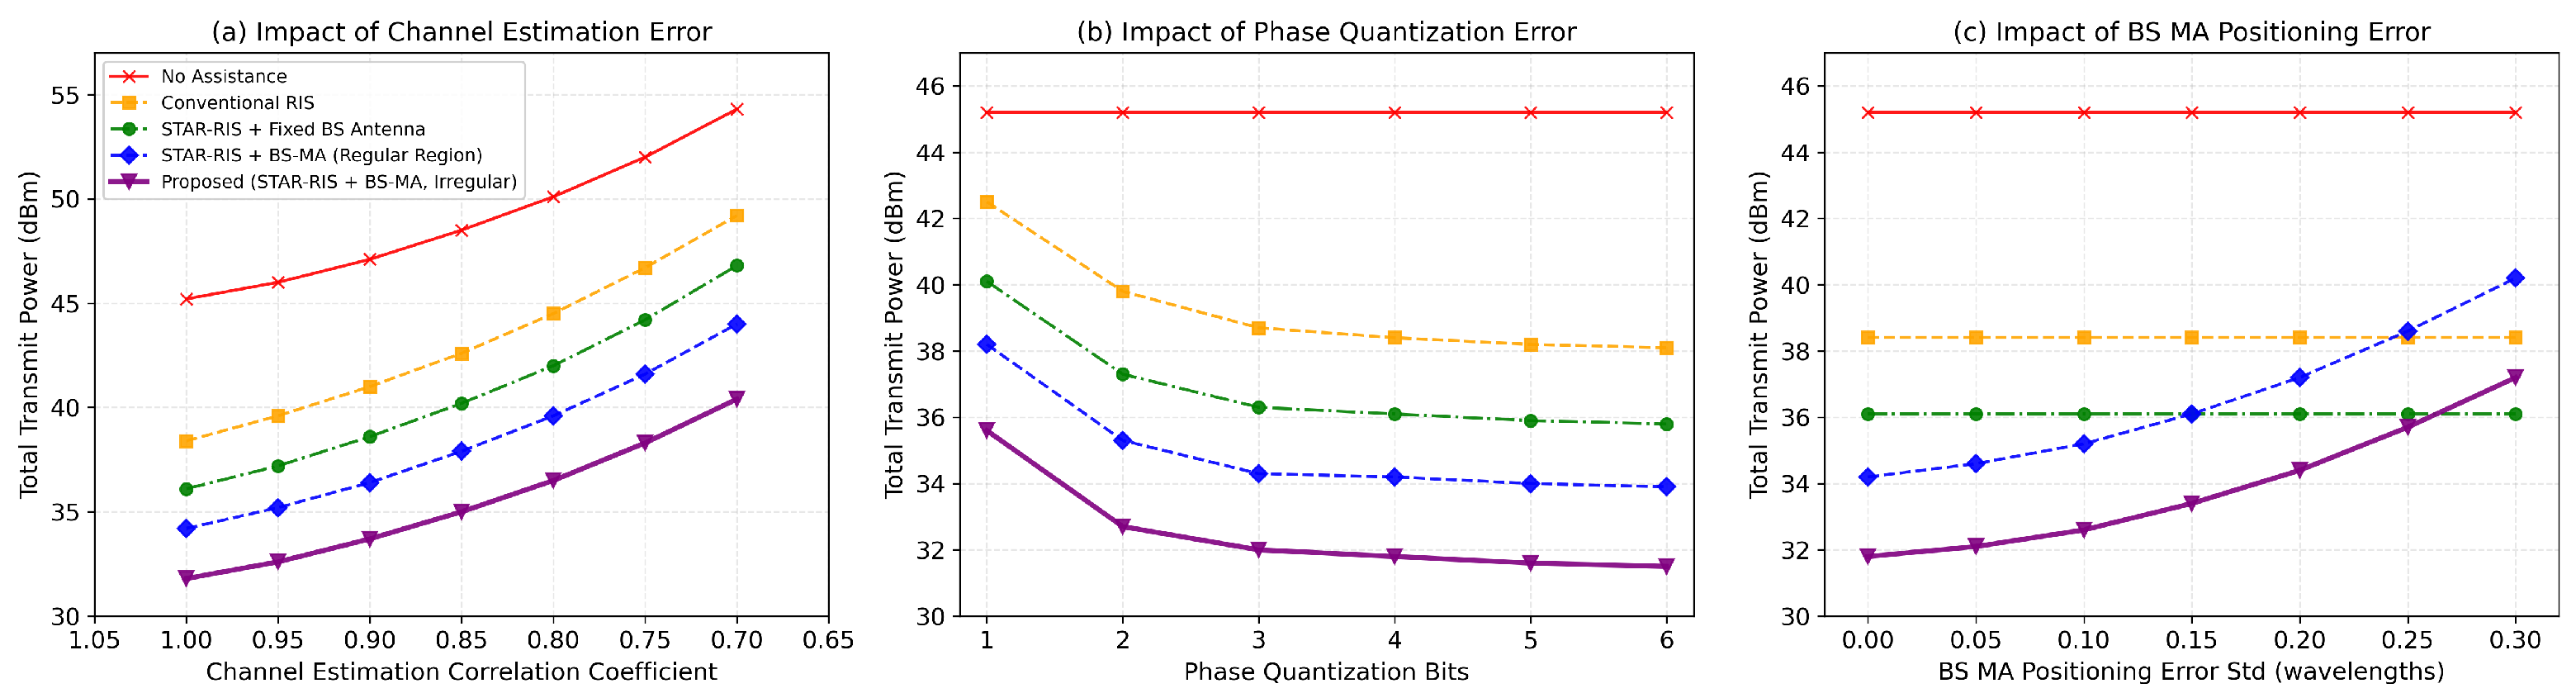
To evaluate robustness under the practical constraint of imperfect CSI, Figure 6a shows system performance as the channel estimation correlation coefficient decreases from 1.0 (perfect CSI) to 0.7. Figure 6 evaluates the robustness of the proposed scheme under three practical implementation imperfections.
Figure 6.
System robustness under practical implementation imperfections with devices, STAR-RIS elements, and dBm.
Channel Estimation Error (Figure 6a): As the channel estimation correlation coefficient decreases from 1.0 to 0.7, the proposed scheme incurs only 3.2 dB additional power, which is the smallest degradation among all schemes. The regular-region baseline degrades more rapidly, confirming that the irregular partitioning design provides additional robustness under practical hardware constraints, reducing sensitivity to individual channel estimation errors.
Phase Quantization (Figure 6b): Performance saturates at three to four quantization bits for all RIS-based schemes, confirming that low-resolution phase shifters are sufficient for practical coal mine deployments without significant performance loss.
BS-side MA Positioning Error (Figure 6c): The proposed scheme tolerates BS-side MA positioning errors up to with less than 0.8 dB power increase, well within the mechanical precision of BS-side antenna actuators. Beyond , performance degrades gracefully and remains superior to all baseline schemes up to .
4.6. Performance Under Coal Mine Environmental Variations
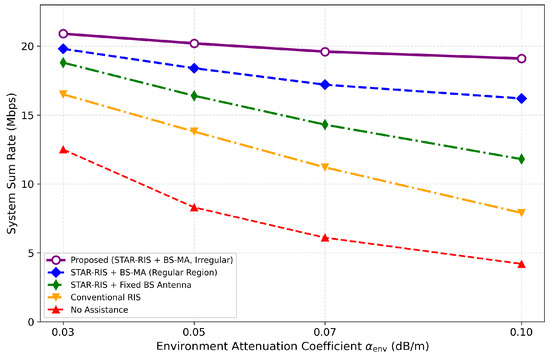
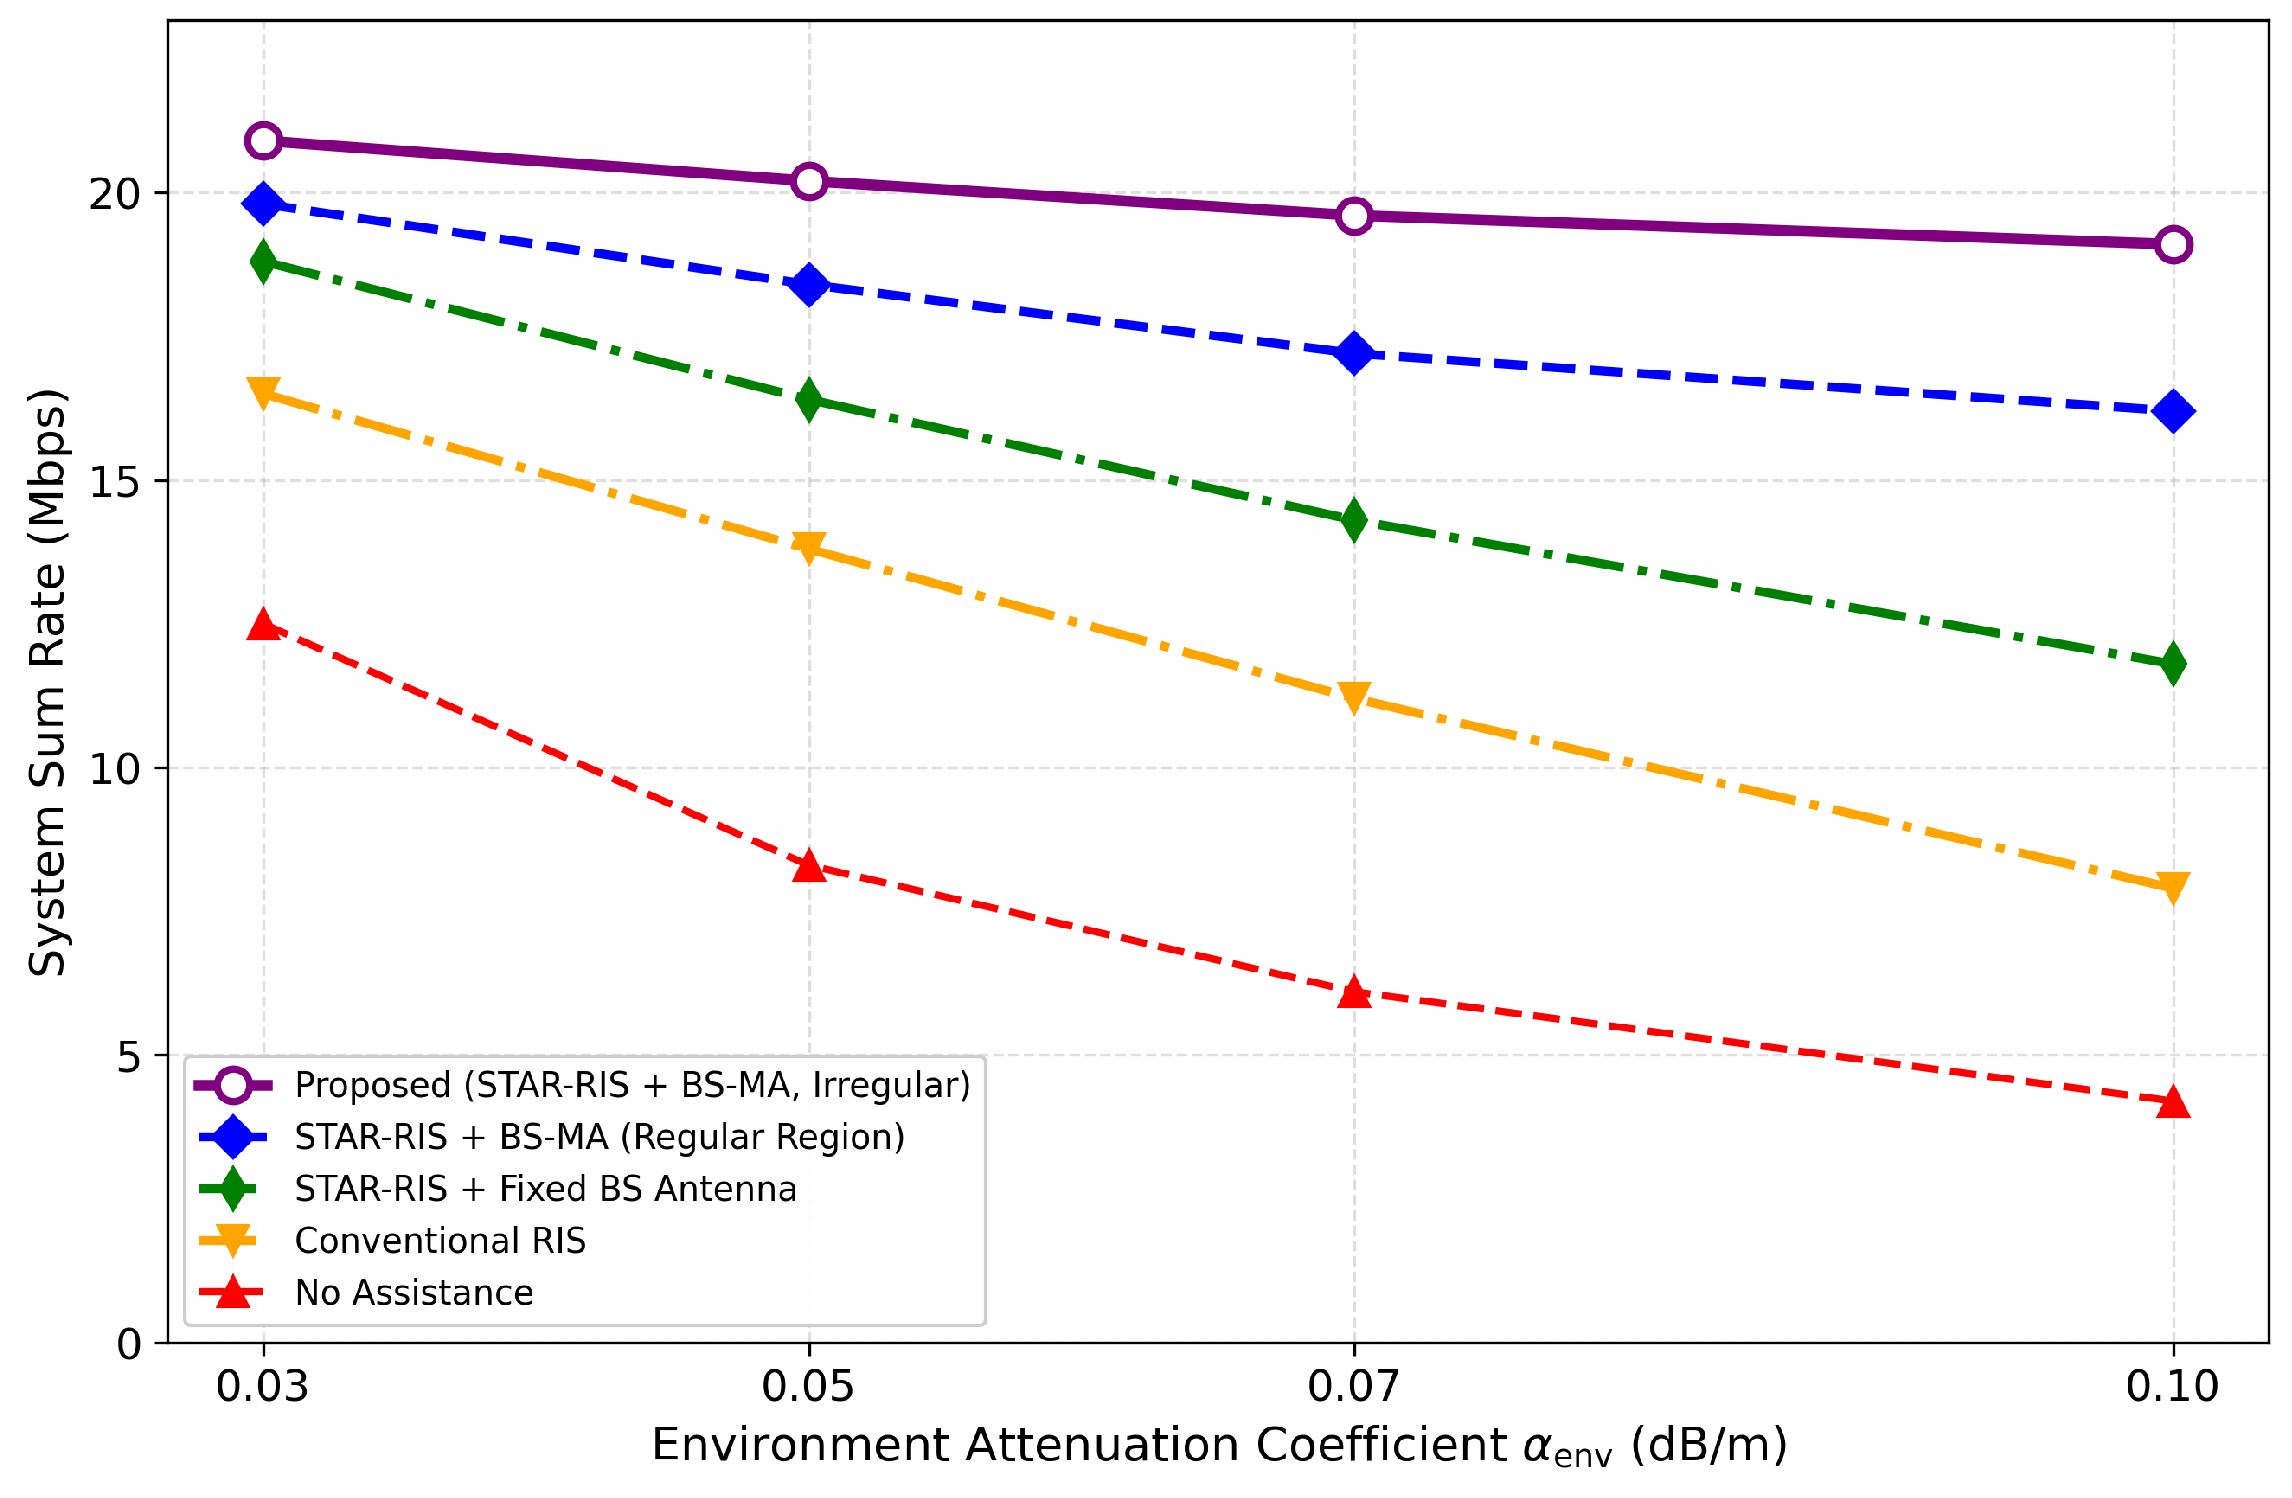
To validate the robustness of the proposed scheme under realistic coal mine conditions, we evaluate system performance across varying environmental attenuation levels. Figure 7 shows the sum rate as increases from 0.03 to 0.10 dB/m, representing progressively harsher underground conditions.
Figure 7.
System sum rate comparison under varying coal mine environmental attenuation coefficients with devices, STAR-RIS elements, and dBm.
The proposed scheme maintains exceptional stability, degrading only 8.6% from clean to severe attenuation conditions. The regular-region baseline degrades by approximately 18.2%, more than twice the degradation of the proposed scheme, confirming that the irregular partitioned subregion design provides additional robustness by enabling the Hungarian-based assignment to relocate MAs toward subregions with better channel conditions as attenuation increases. In contrast, the fixed-antenna baselines suffer much larger losses: STAR-RIS with fixed BS antennas degrades by 37.2%, conventional RIS by 52.1%, and the no-assistance baseline by 66.4%.
The observed robustness can be traced to three coupled adaptation mechanisms: (1) the global reassignment mechanism periodically re-evaluates the quality matrix and reassigns BS-side MAs to subregions with the best instantaneous channel conditions via the Hungarian algorithm, adapting to increased path loss; (2) the STAR-RIS energy splitting dynamically reallocates power between transmission and reflection paths, maintaining path diversity when one link is severely attenuated; (3) the beamforming optimization distributes transmit power toward devices experiencing stronger environmental degradation. These results confirm that the joint optimization of BS-side MA assignment, beamforming, and STAR-RIS coefficients is essential for maintaining reliable communication in harsh coal mine environments.
5. Practical Considerations
Hardware Cost and Actuator Precision: The proposed BS-side MA system requires motorized actuators for antenna repositioning within the irregular subregions. Commercial stepper motors with positioning precision below are available at moderate cost, consistent with the robustness results in Figure 6c.
Energy Consumption: Antenna repositioning is performed on a per-coherence-block basis. Since repositioning occurs only when the channel quality matrix changes significantly (every –10 iterations), the mechanical energy overhead is negligible compared to the RF transmission power of 50 dBm.
Control Signaling Overhead: The subregion assignment and MA positions are updated at the BS side only and do not require additional feedback from the IoT devices. The STAR-RIS phase shifts require a low-rate control link, consistent with standard RIS deployment assumptions [10].
Computational Latency: As analyzed above, the dominant per-iteration complexity is . For , each BCD iteration completes within approximately 0.3 s on a standard desktop (Intel i7, MATLAB), which is compatible with the quasi-static fading assumption and coherence time ms adopted in Section 2.2.4.
6. Conclusions
This paper studies a STAR-RIS-assisted underground coal mine communication system with multiple BS-side MAs under hardware-constrained deployment geometry. The key modeling step is to represent the BS panel as irregular non-overlapping feasible subregions rather than an ideal continuous region, which leads to an assignment-coupled MINLP for MA positioning. We solve the resulting joint problem using a BCD framework that combines SCA/SDR updates with a penalty-based MA solver enhanced by reassignment and cross-region jump mechanisms.
Across coal mine simulation settings, the proposed design improves system sum rate by 66.7% and reduces required BS transmit power by up to 16.8 dB compared with fixed-antenna baselines. Relative to a regular-region MA baseline, the irregular-partition model provides an additional 5.6 dB power saving, confirming that hardware-aware feasible-region modeling is not a cosmetic detail but a performance-relevant factor. Notably, under harsh attenuation conditions ( dB/m), the proposed scheme degrades only 8.6% versus 37–66% for baseline schemes, validating robust adaptation through joint optimization. These results support BS-side MA and STAR-RIS co-design as a practical direction for robust underground wireless systems.
Author Contributions
Author Contributions: Conceptualization, Y.X. and T.G.; methodology, Y.X. and T.G.; software, Y.X.; validation, Y.X., Y.Y. and X.L.; formal analysis, Y.X. and Y.Y.; investigation, Y.X. and X.L.; resources, Y.Z. and W.L.; data curation, Y.X.; writing—original draft preparation, Y.X.; writing—review and editing, T.G. and Y.X.; visualization, Y.X. and Y.Y.; supervision, T.G.; project administration, T.G.; funding acquisition, T.G. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded in part by the Shanxi Scholarship Council of China under Grant 2023-005, and in part by the Fundamental Research Program of Shanxi Province under Grant 202303021212014.
Data Availability Statement
Data are available from the First author Yuxin Xia upon reasonable request.
Acknowledgments
The authors would like to thank the State Key Laboratory of Integrated Services Networks (ISN), Xidian University, for providing research support.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Bandyopadhyay, L.K.; Chaulya, S.K.; Mishra, P.K. Wireless Communication in Underground Mines: RFID-Based Sensor Networking; Springer: Boston, MA, USA, 2010. [Google Scholar]
- Misra, P.; Kanhere, S.; Ostry, D.; Jha, S. Safety assurance and rescue communication systems in high-stress environments: A mining case study. IEEE Commun. Mag. 2010, 48, 66–73. [Google Scholar] [CrossRef] [Scilit]
- Moridi, M.A.; Kawamura, Y.; Sharifzadeh, M.; Chanda, E.K.; Jang, H. An investigation of underground monitoring and communication system based on radio waves attenuation using ZigBee. Tunn. Undergr. Space Technol. 2014, 43, 362–369. [Google Scholar] [CrossRef] [Scilit]
- Ranjan, A.; Sahu, H.; Sahu, H.B. Communications challenges in underground mines. Int. J. Eng. Trends Technol. 2014, 5, 23–29. [Google Scholar]
- Chowdhury, A.R.; Pramanik, A.; Roy, G.C. IoT and LoRa based smart underground coal mine monitoring system. Microsyst. Technol. 2023, 29, 919–938. [Google Scholar] [CrossRef] [Scilit]
- Jo, B.W.; Khan, R.M.A.; Javaid, O. Arduino-based intelligent gases monitoring and information sharing Internet-of-Things system for underground coal mines. J. Ambient Intell. Smart Environ. 2019, 11, 183–194. [Google Scholar] [CrossRef] [Scilit]
- Mishra, P.K.; Kumar, S.; Pratik, P.; Kumar, M.; Kumar, J. IoT based multimode sensing platform for underground coal mines. Wirel. Pers. Commun. 2019, 108, 1227–1242. [Google Scholar] [CrossRef] [Scilit]
- Wu, C.; You, C.; Liu, Y.; Gu, X.; Cai, Y. Channel Estimation for STAR-RIS-Aided Wireless Communication. IEEE Commun. Lett. 2021, 26, 652–656. [Google Scholar] [CrossRef] [Scilit]
- Basar, E.; Di Renzo, M.; De Rosny, J.; Debbah, M.; Alouini, M.S.; Zhang, R. Wireless communications through reconfigurable intelligent surfaces. IEEE Access 2019, 7, 116753–116773. [Google Scholar] [CrossRef] [Scilit]
- Wu, Q.; Zhang, R. Towards smart and reconfigurable environment: Intelligent reflecting surface aided wireless network. IEEE Commun. Mag. 2019, 58, 106–112. [Google Scholar] [CrossRef] [Scilit]
- Xu, J.; Liu, Y.; Mu, X.; Dobre, O.A. STAR-RISs: Simultaneous transmitting and reflecting reconfigurable intelligent surfaces. IEEE Commun. Lett. 2021, 25, 3134–3138. [Google Scholar] [CrossRef] [Scilit]
- Mu, X.; Liu, Y.; Guo, L.; Lin, J.; Schober, R. Simultaneously transmitting and reflecting (STAR) RIS aided wireless communications. IEEE Trans. Wirel. Commun. 2021, 21, 3083–3098. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Z.; Dai, L.; Chen, X.; Liu, C.; Yang, F.; Schober, R.; Poor, H.V. Active RIS vs. passive RIS: Which will prevail in 6G? IEEE Trans. Commun. 2022, 71, 1707–1725. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Zhang, R.; Jiang, R.; Zhu, Y.; Hu, H.; Ni, Q.; Fei, Z.; Niyato, D. STAR-RIS Enabled ISAC Systems with RSMA: Joint Rate Splitting and Beamforming Optimization. IEEE Trans. Cogn. Commun. Netw. 2025, 12, 312–326. [Google Scholar] [CrossRef] [Scilit]
- Zhou, X.; Ke, F.; Wu, C.; Zhang, X.Y.; Ng, D.W.K. Robust Beamforming for STAR-RIS Aided Hybrid-Field ISAC Systems. IEEE Trans. Commun. 2026, 74, 5654–5669. [Google Scholar] [CrossRef] [Scilit]
- Zhou, T.; Xu, K.; Hu, G.; Li, C.; Xia, X.; Wei, C.; Chen, Y. STAR-RIS-Empowered Integrated Sensing and Covert Communication System with Movable Elements: Joint Robust Beamforming and Element Deployment Design. IEEE Trans. Cogn. Commun. Netw. 2025, 11, 2893–2909. [Google Scholar] [CrossRef] [Scilit]
- Di Renzo, M.; Zappone, A.; Debbah, M.; Alouini, M.S.; Yuen, C.; De Rosny, J.; Tretyakov, S. Smart radio environments empowered by reconfigurable intelligent surfaces: How it works, state of research, and the road ahead. IEEE J. Sel. Areas Commun. 2020, 38, 2450–2525. [Google Scholar] [CrossRef] [Scilit]
- Zhu, L.; Ma, W.; Ning, B.; Zhang, R. Movable-Antenna Enhanced Multiuser Communication via Antenna Position Optimization. IEEE Trans. Wirel. Commun. 2023, 23, 7214–7229. [Google Scholar] [CrossRef] [Scilit]
- Wong, K.K.; Shojaeifard, A.; Tong, K.F.; Zhang, Y. Fluid Antenna Systems. IEEE Trans. Wirel. Commun. 2020, 20, 1950–1962. [Google Scholar] [CrossRef] [Scilit]
- Mei, W.; Zheng, B.; You, C.; Zhang, R. Movable-antenna position optimization: A graph-based approach. IEEE Wirel. Commun. Lett. 2024, 13, 1042–1046. [Google Scholar] [CrossRef] [Scilit]
- Dong, Z.; Zhou, Z.; Xiao, Z.; Zhang, C.; Li, X.; Min, H.; Zeng, Y.; Jin, S.; Zhang, R. Movable Antenna for Wireless Communications: Prototyping and Experimental Results. IEEE Trans. Wirel. Commun. 2025, 25, 6586–6599. [Google Scholar] [CrossRef] [Scilit]
- Chen, L.; Zhao, M.M.; Zhao, M.J.; Zhang, R. Antenna Position and Beamforming Optimization for Movable Antenna Enabled ISAC: Optimal Solutions and Efficient Algorithms. IEEE Trans. Signal Process. 2025, 73, 3812–3828. [Google Scholar] [CrossRef] [Scilit]
- Yan, G.; Zhu, L.; Zhang, R. Movable Antenna Aided Multiuser Communications: Antenna Position Optimization Based on Statistical Channel Information. IEEE Trans. Commun. 2025, 74, 1793–1810. [Google Scholar] [CrossRef] [Scilit]
- Shao, Y.; Gulliver, T.A. Transceiver Optimization for Multiuser Multiple-Input Multiple-Output Full-Duplex Amplify-and-Forward Relay Downlink Communications. Telecom 2024, 5, 11. [Google Scholar] [CrossRef] [Scilit]
- Wu, H.; Ren, H.; Pan, C.; Zhang, Y. Movable Antenna-Enabled RIS-Aided Integrated Sensing and Communication. IEEE Trans. Cogn. Commun. Netw. 2025, 11, 2879–2892. [Google Scholar] [CrossRef] [Scilit]
- Amiri, M.; Mohammadzadeh, A.; Zeinali, F.; Mili, M.R.; Mashhadi, M.B.; Xiao, P. Movable Antenna SWIPT Systems with STAR-RIS: A Meta DRL Approach. IEEE Trans. Veh. Technol. 2025, 75, 6864–6869. [Google Scholar] [CrossRef] [Scilit]
- Geng, Y.; Cheng, T.H.; Zhong, K.; Teh, K.C.; Wu, Q. Joint Beamforming and Antenna Position Optimization for IRS-Aided Multi-User Movable Antenna Systems. IEEE Trans. Wirel. Commun. 2025, 25, 3750–3765. [Google Scholar] [CrossRef] [Scilit]
- Ma, Y.; Liu, K.; Liu, Y.; Zhu, L.; Xiao, Z. Movable-Antenna Aided Secure Transmission for RIS-ISAC Systems. IEEE Trans. Wirel. Commun. 2025, 24, 10019–10035. [Google Scholar] [CrossRef] [Scilit]
- Huang, C.; Zappone, A.; Alexandropoulos, G.C.; Debbah, M.; Yuen, C. Reconfigurable intelligent surfaces for energy efficiency in wireless communication. IEEE Trans. Wirel. Commun. 2019, 18, 4157–4170. [Google Scholar] [CrossRef] [Scilit]
- Keawin, C.; Innok, A.; Uthansakul, P. Optimization of Signal Detection Using Deep CNN in Ultra-Massive MIMO. Telecom 2024, 5, 280–295. [Google Scholar] [CrossRef] [Scilit]
- Zhou, D.; Mei, W.; Bai, Z.; Li, N.; Quek, T.Q.S. Movable-Element RIS: Joint Element Positioning and Beamforming Optimization. IEEE Wirel. Commun. Lett. 2025, 15, 915–919. [Google Scholar] [CrossRef] [Scilit]
- Li, X.; Yan, Y.; Guo, T.; Xu, L.; Yang, Z.; Zhang, X.; Wan, K. Position-Flexible STAR-RIS-Assisted Wireless Networks in Coal Mines: Location and Beamforming Design. IEEE Internet Things J. 2026. Early Access. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Liu, X.; Mu, X.; Hou, T.; Xu, J.; Di Renzo, M.; Al-Dhahir, N. Reconfigurable intelligent surfaces: Principles and opportunities. IEEE Commun. Surv. Tutor. 2021, 23, 1546–1577. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Zhu, L.; Han, S.; Sun, H.; Zhang, R. Joint Antenna Positioning and Beamforming for Movable Antenna Array Aided Ground Station in Low-Earth Orbit Satellite Communication. IEEE Trans. Wirel. Commun. 2025, 25, 9437–9451. [Google Scholar] [CrossRef] [Scilit]
- Zeng, X.; Fang, J.; Wang, B.; Ning, B.; Li, H. CSI-Free Position Optimization for Movable Antenna Communication Systems: A Derivative-Free Optimization Approach. IEEE Wirel. Commun. Lett. 2024, 14, 53–57. [Google Scholar] [CrossRef] [Scilit]
- Worka, C.E.; Khan, F.A.; Ahmed, Q.Z.; Sureephong, P.; Alade, T. Joint Placement Optimization and Sum Rate Maximization of RIS-Assisted UAV with LEO-Terrestrial Dual Wireless Backhaul. Telecom 2025, 6, 61. [Google Scholar]
- Bertsekas, D.P. Nonlinear Programming, 2nd ed.; Athena Scientific: Belmont, MA, USA, 1999. [Google Scholar]
- Kheder, R.; Ghayoula, R.; Smida, A.; El Gmati, I.; Latrach, L.; Amara, W.; Hammami, A.; Fattahi, J.; Waly, M.I. Enhancing Beamforming Efficiency Utilizing Taguchi Optimization and Neural Network Acceleration. Telecom 2024, 5, 451–475. [Google Scholar] [CrossRef] [Scilit]
- Boyd, S.; Vandenberghe, L. Convex Optimization; Cambridge University Press: Cambridge, UK, 2004. [Google Scholar]
- Razaviyayn, M.; Hong, M.; Luo, Z.-Q. A unified convergence analysis of block successive minimization methods for nonsmooth optimization. SIAM J. Optim. 2013, 23, 1126–1153. [Google Scholar] [CrossRef] [Scilit]
- Luo, Z.-Q.; Ma, W.-K.; So, A.M.-C.; Ye, Y.; Zhang, S. Semidefinite relaxation of quadratic optimization problems. IEEE Signal Process. Mag. 2010, 27, 20–34. [Google Scholar] [CrossRef] [Scilit]
- Nocedal, J.; Wright, S.J. Numerical Optimization, 2nd ed.; Springer: New York, NY, USA, 2006. [Google Scholar]
- Sun, Y.; Babu, P.; Palomar, D.P. Majorization-minimization algorithms in signal processing, communications, and machine learning. IEEE Trans. Signal Process. 2016, 65, 794–816. [Google Scholar] [CrossRef] [Scilit]
- Goldsmith, A. Wireless Communications; Cambridge University Press: Cambridge, UK, 2005. [Google Scholar]
- Kumar, S.; Chandra, G.; Chaulya, S.K.; Shekhar, M. Modeling and measurements for wireless communication networks in underground mine environments. Measurement 2020, 149, 106980. [Google Scholar] [CrossRef] [Scilit]
- Tse, D.; Viswanath, P. Fundamentals of Wireless Communication; Cambridge University Press: Cambridge, UK, 2005. [Google Scholar]
- Sayeed, A.M. Deconstructing multiantenna fading channels. IEEE Trans. Signal Process. 2002, 50, 2563–2579. [Google Scholar] [CrossRef] [Scilit]
- Javaid, F.; Wang, A.; Sana, M.U.; Husain, A.; Ashraf, I. An Optimized Approach to Channel Modeling and Impact of Deteriorating Factors on Wireless Communication in Underground Mines. Sensors 2021, 21, 5905. [Google Scholar] [CrossRef] [Scilit]
- Nguyen, N.T.; Nguyen, V.D.; Nguyen, H.V.; Lee, B.M.; Dobre, O.A. Spectral efficiency analysis of hybrid relay-reflecting intelligent surface-assisted cell-free massive MIMO systems. IEEE Trans. Wirel. Commun. 2022, 22, 3397–3416. [Google Scholar] [CrossRef] [Scilit]
- Ishteyaq, I.; Muzaffar, K. Resource Allocation Using Reconfigurable Intelligent Surface (RIS)-Assisted Wireless Networks in Industry 5.0 Scenario. Telecom 2022, 3, 11. [Google Scholar] [CrossRef] [Scilit]
- Kuhn, H.W. The Hungarian method for the assignment problem. Nav. Res. Logist. Q. 1955, 2, 83–97. [Google Scholar] [CrossRef] [Scilit]
- Grant, M.; Boyd, S. CVX: Matlab Software for Disciplined Convex Programming, Version 2.1. Available online: http://cvxr.com/cvx (accessed on 1 March 2014).
- Sinkhorn, R.; Knopp, P. Concerning nonnegative matrices and doubly stochastic matrices. Pac. J. Math. 1967, 21, 343–348. [Google Scholar] [CrossRef] [Scilit]
- Chen, X.; Ng, D.W.K.; Yu, W.; Larsson, E.G.; Al-Dhahir, N.; Schober, R. Massive access for 5G and beyond. IEEE J. Sel. Areas Commun. 2021, 39, 615–637. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.