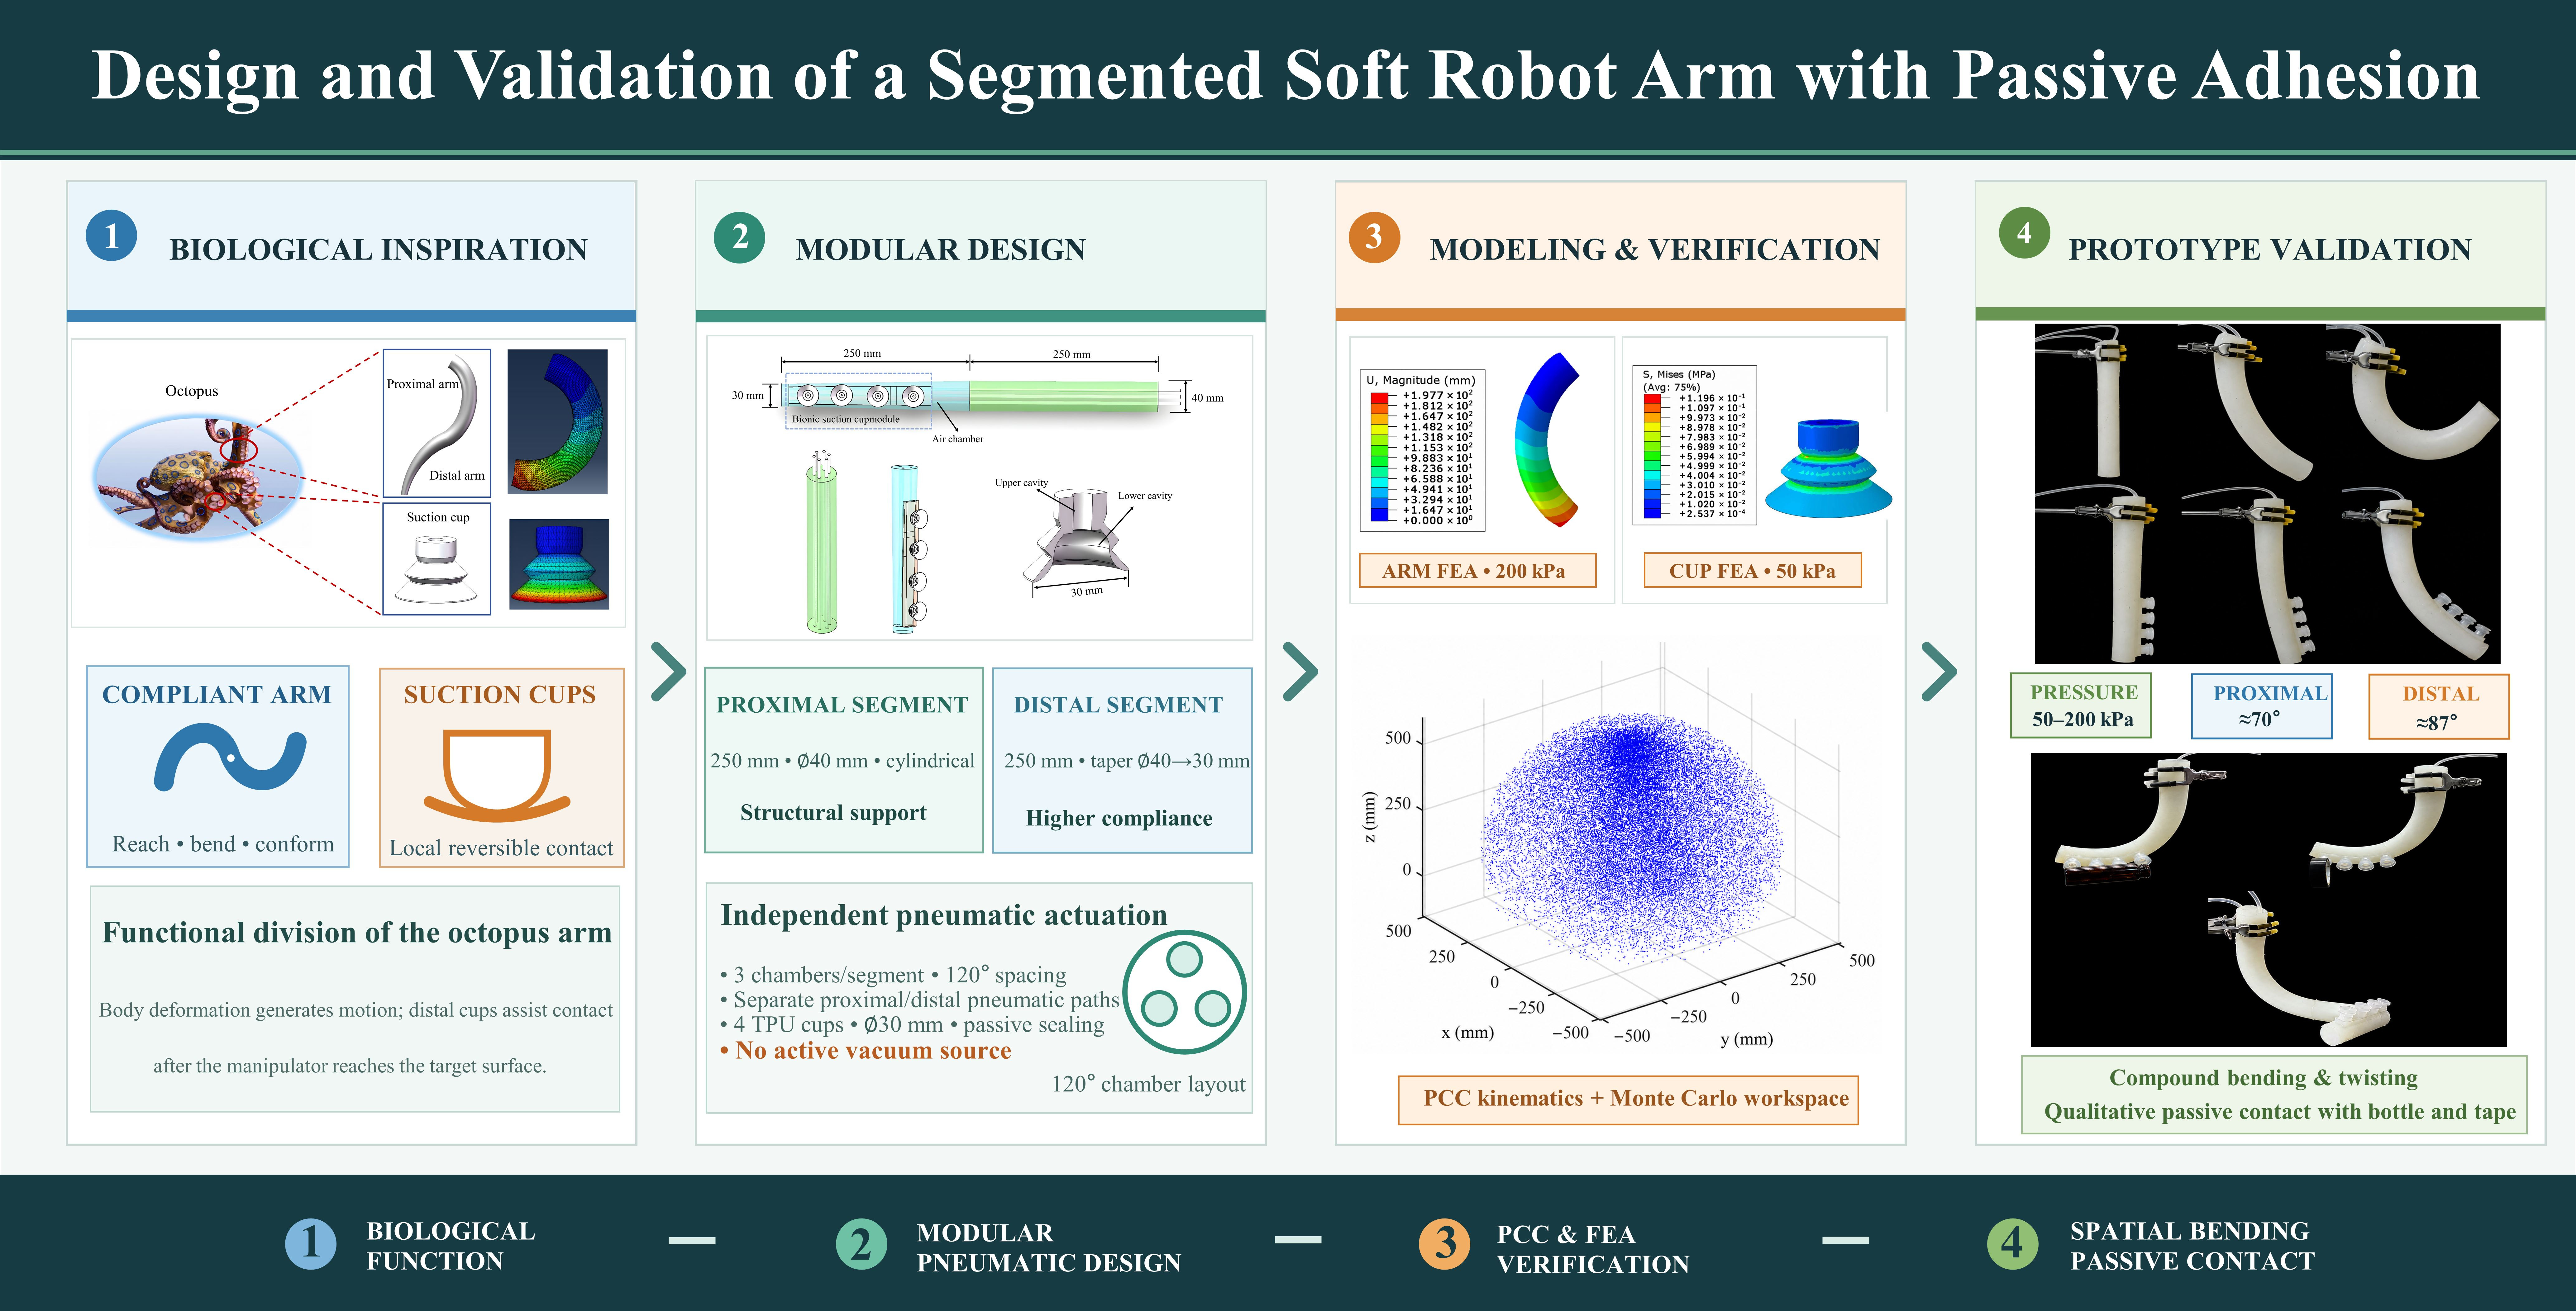

Octopus-Inspired Modular Two-Segment Pneumatic Soft Manipulator with Passive Suction Cups


Abstract

1. Introduction
2. Biomimetic Design and Fabrication
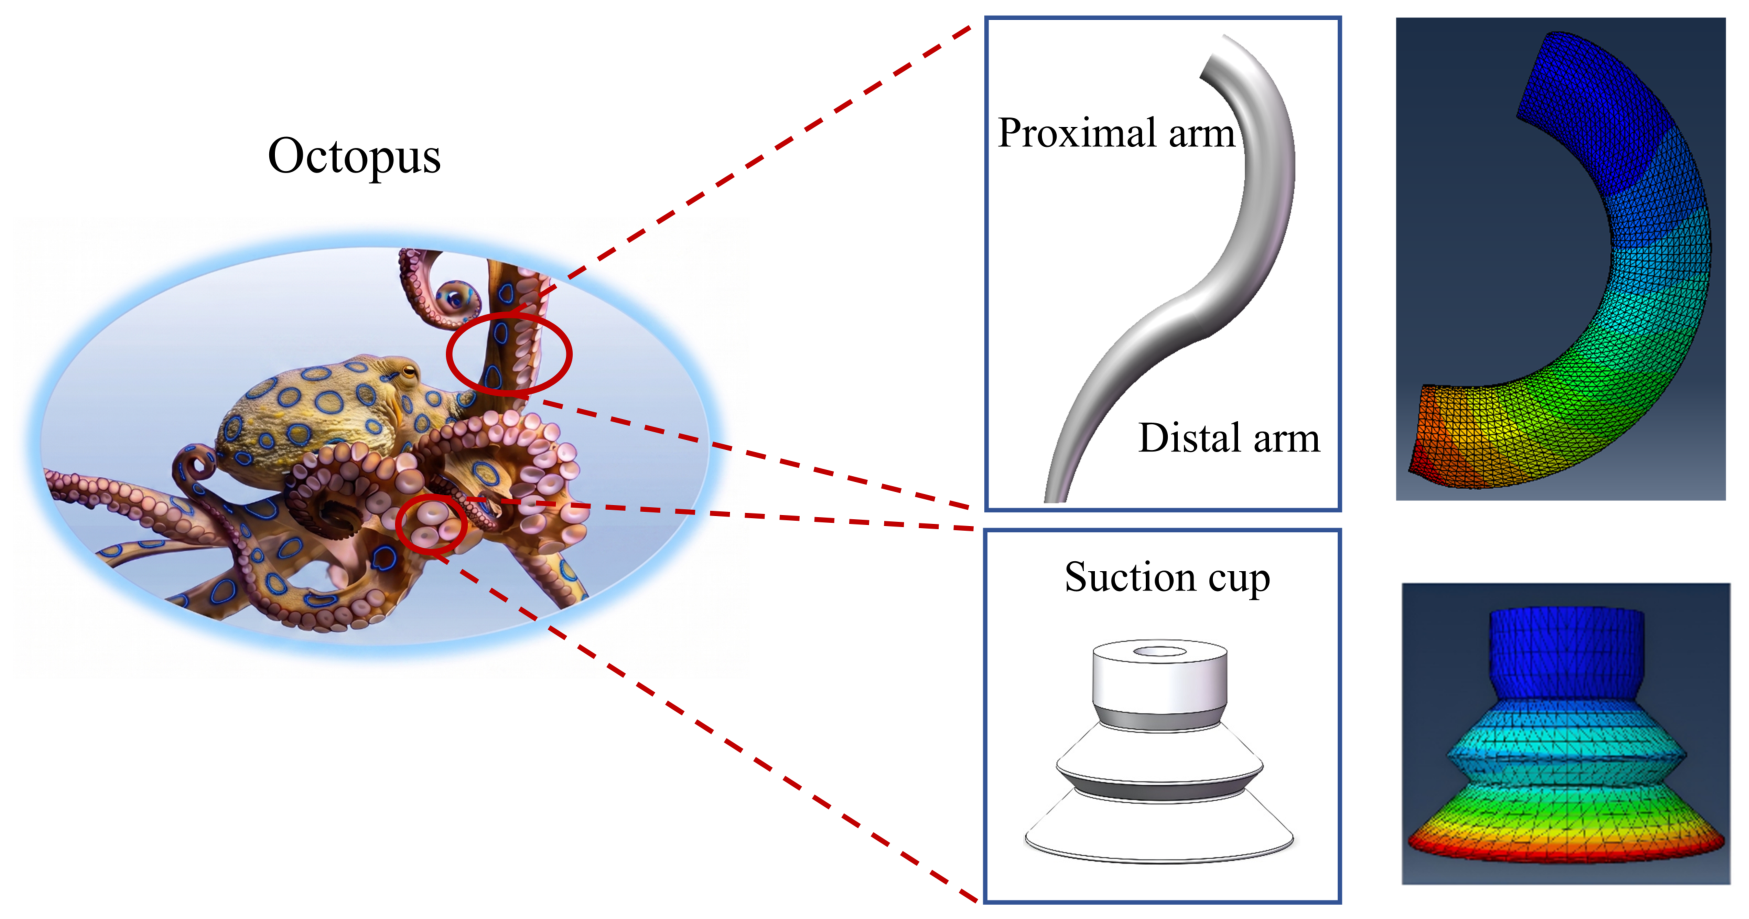
2.1. Biological Inspiration and Design Principle
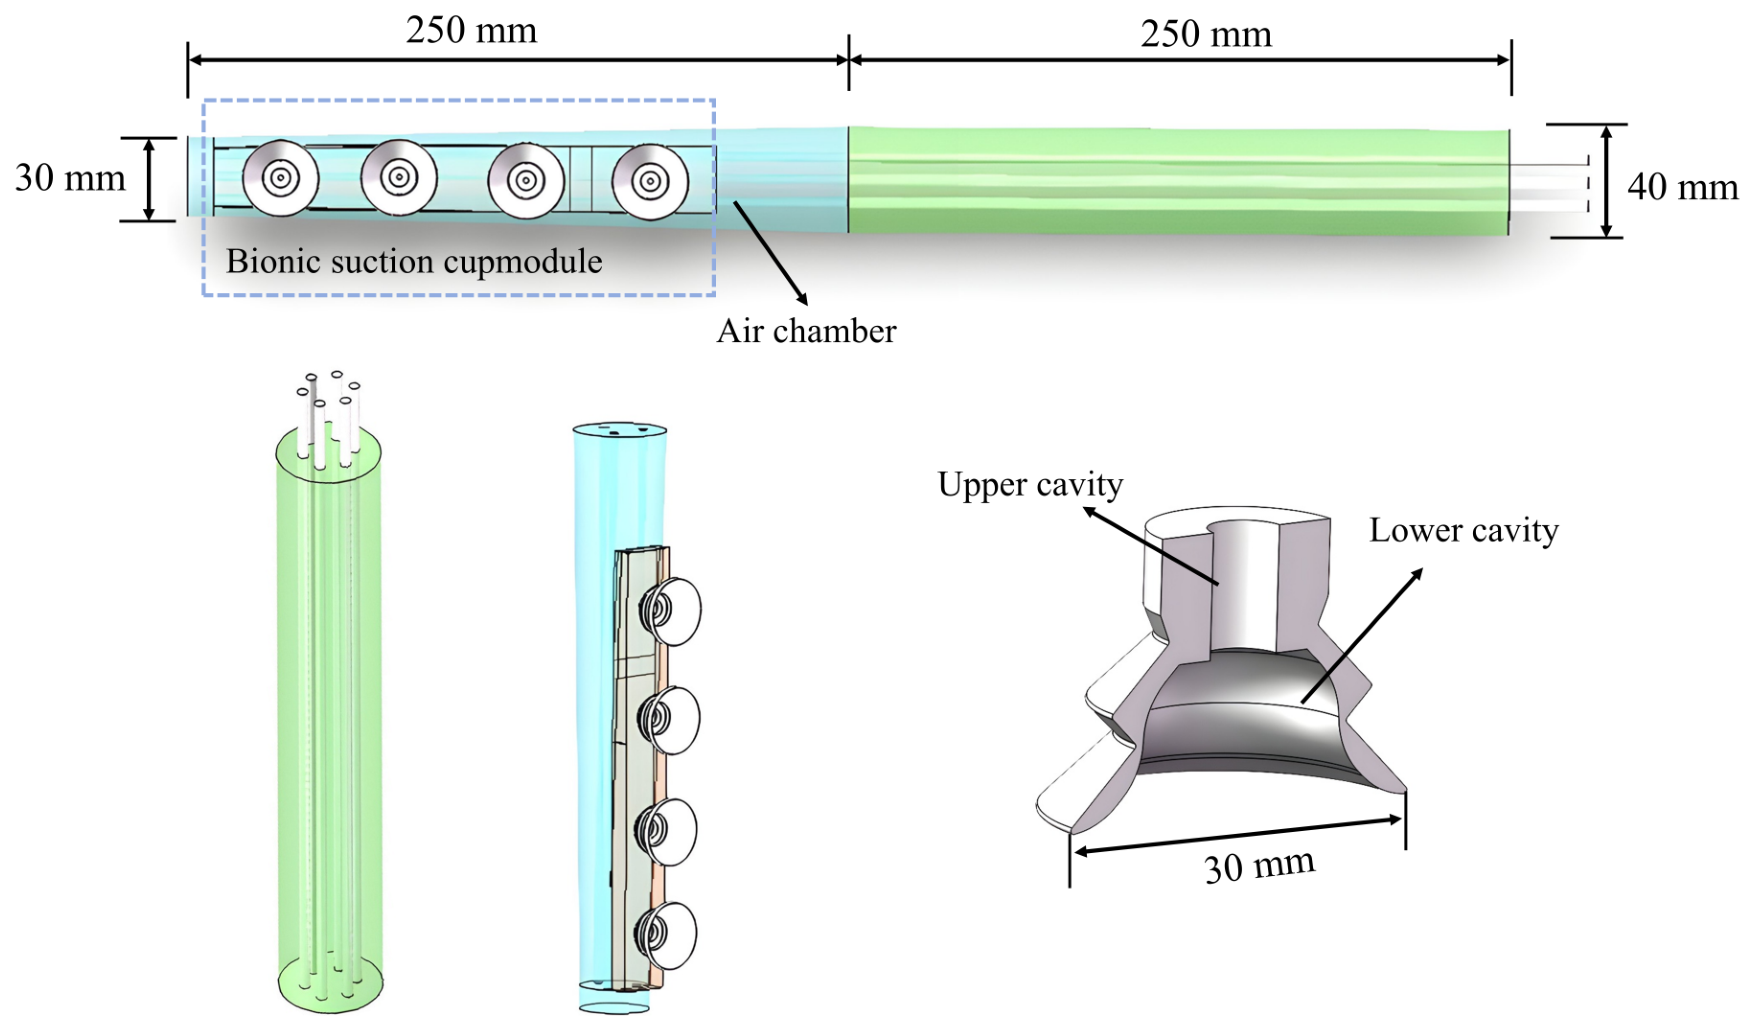
2.2. Manipulator Structure
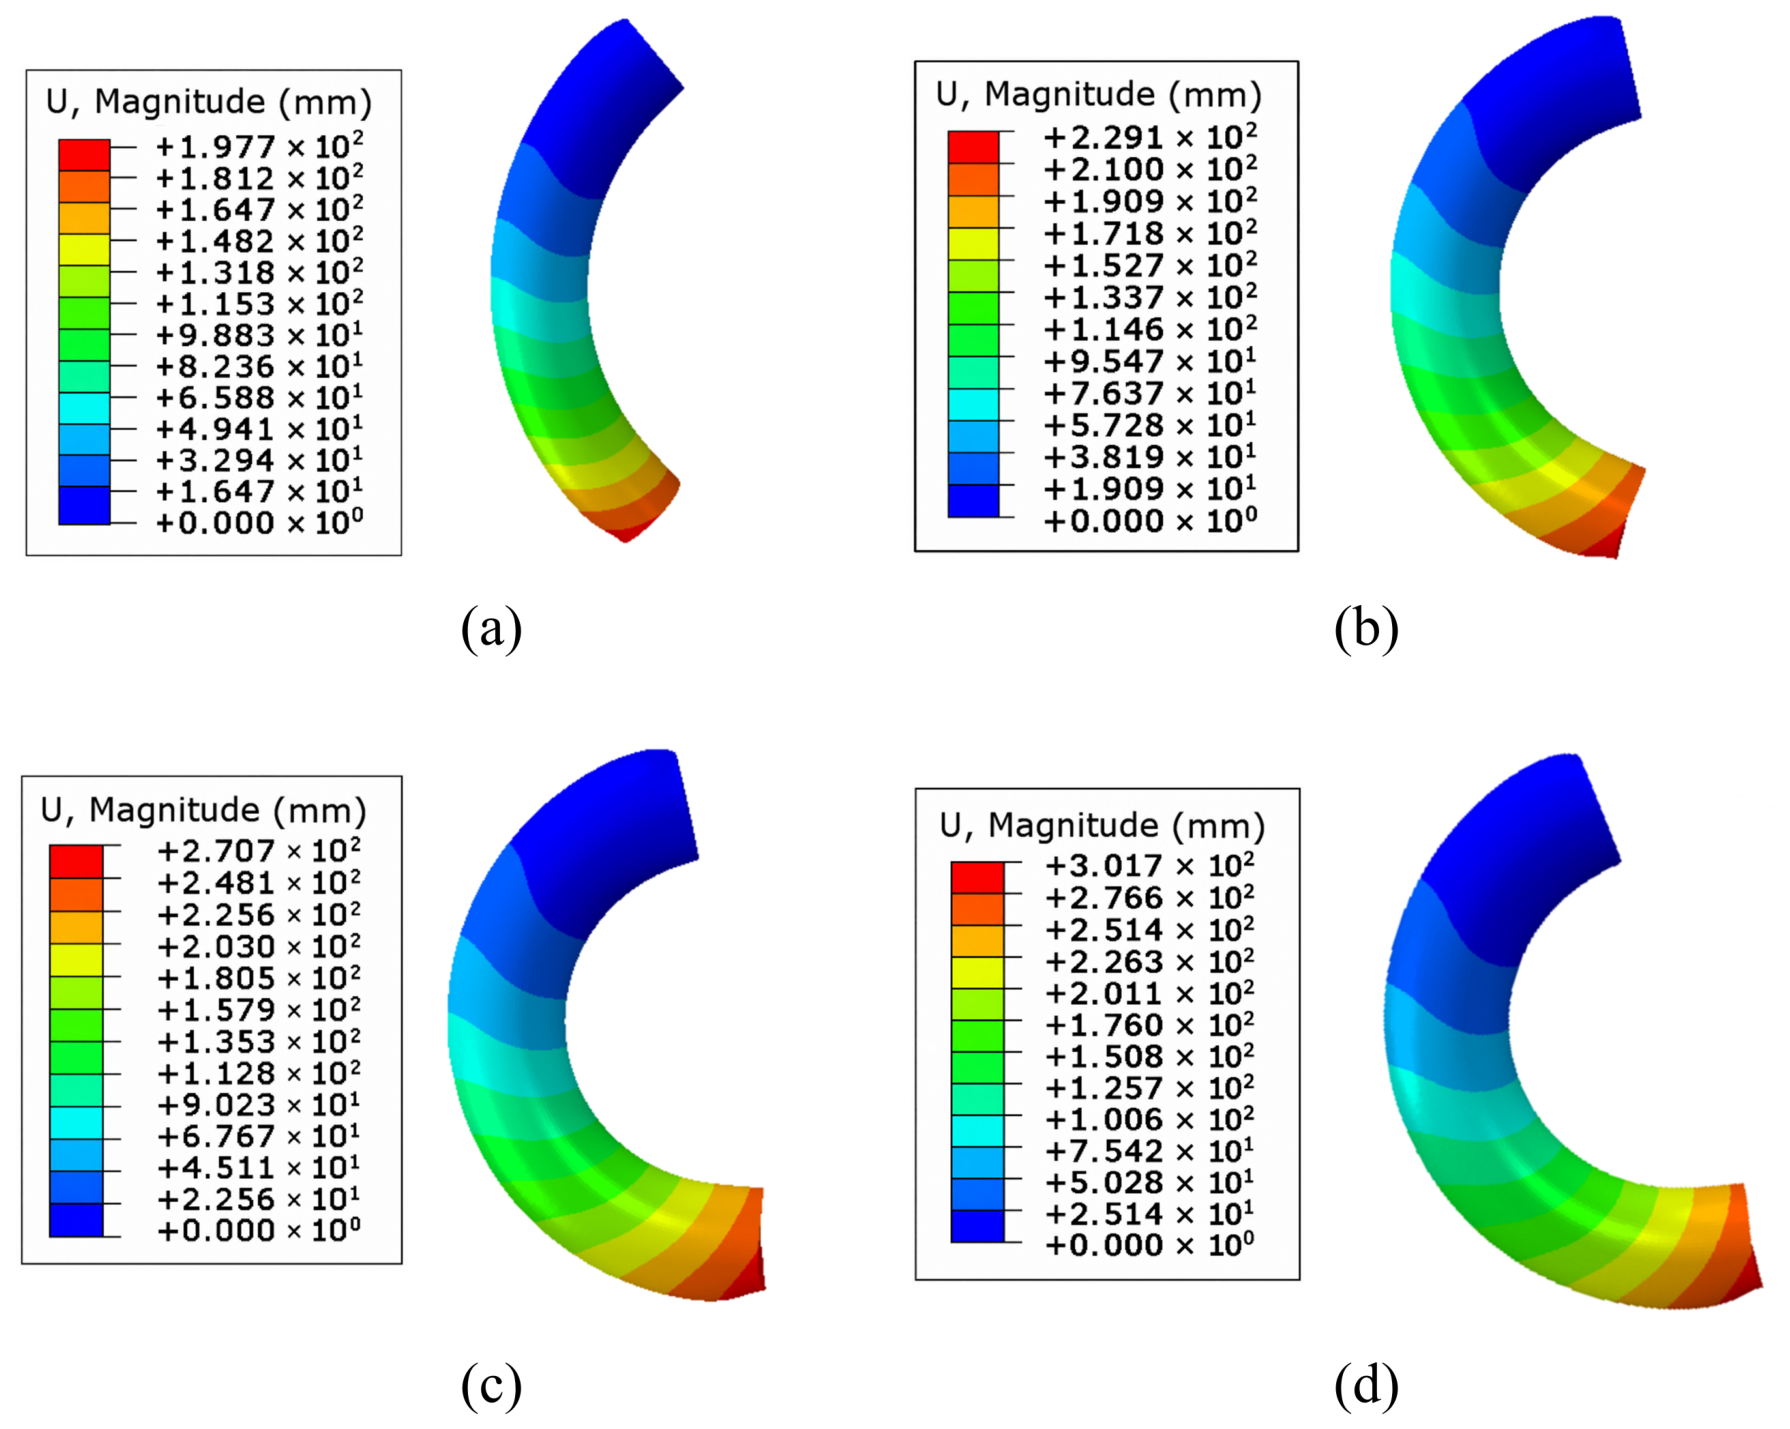
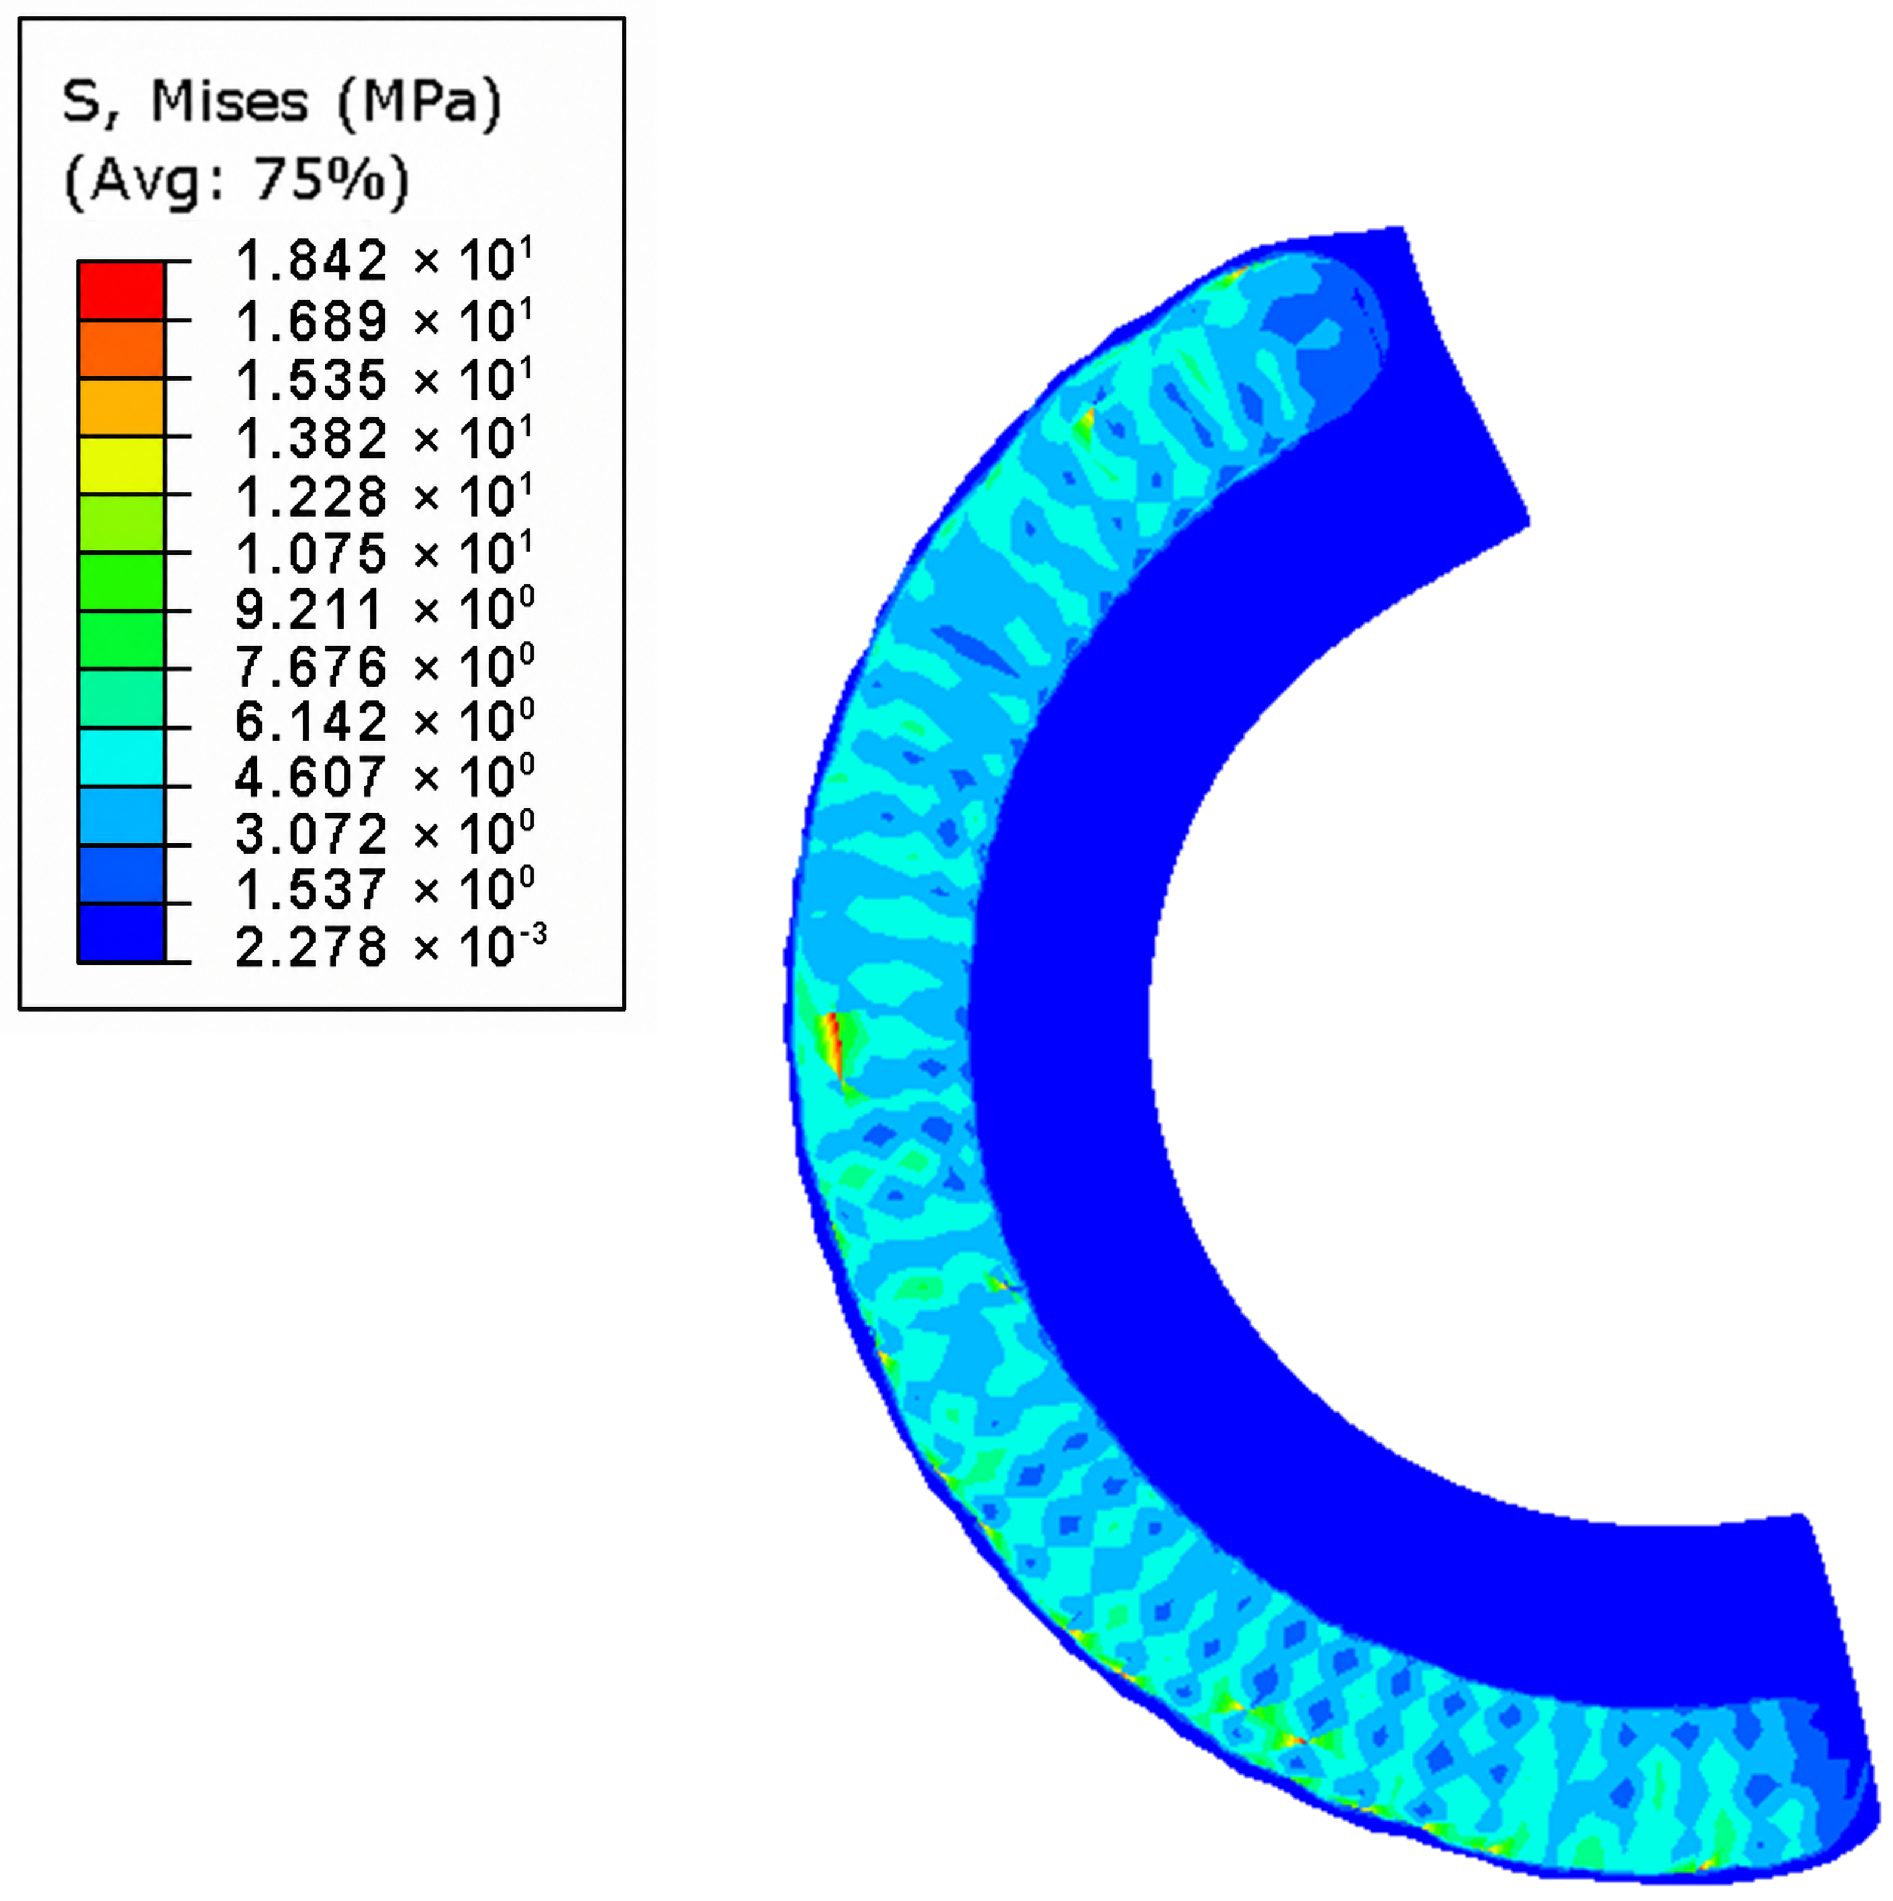
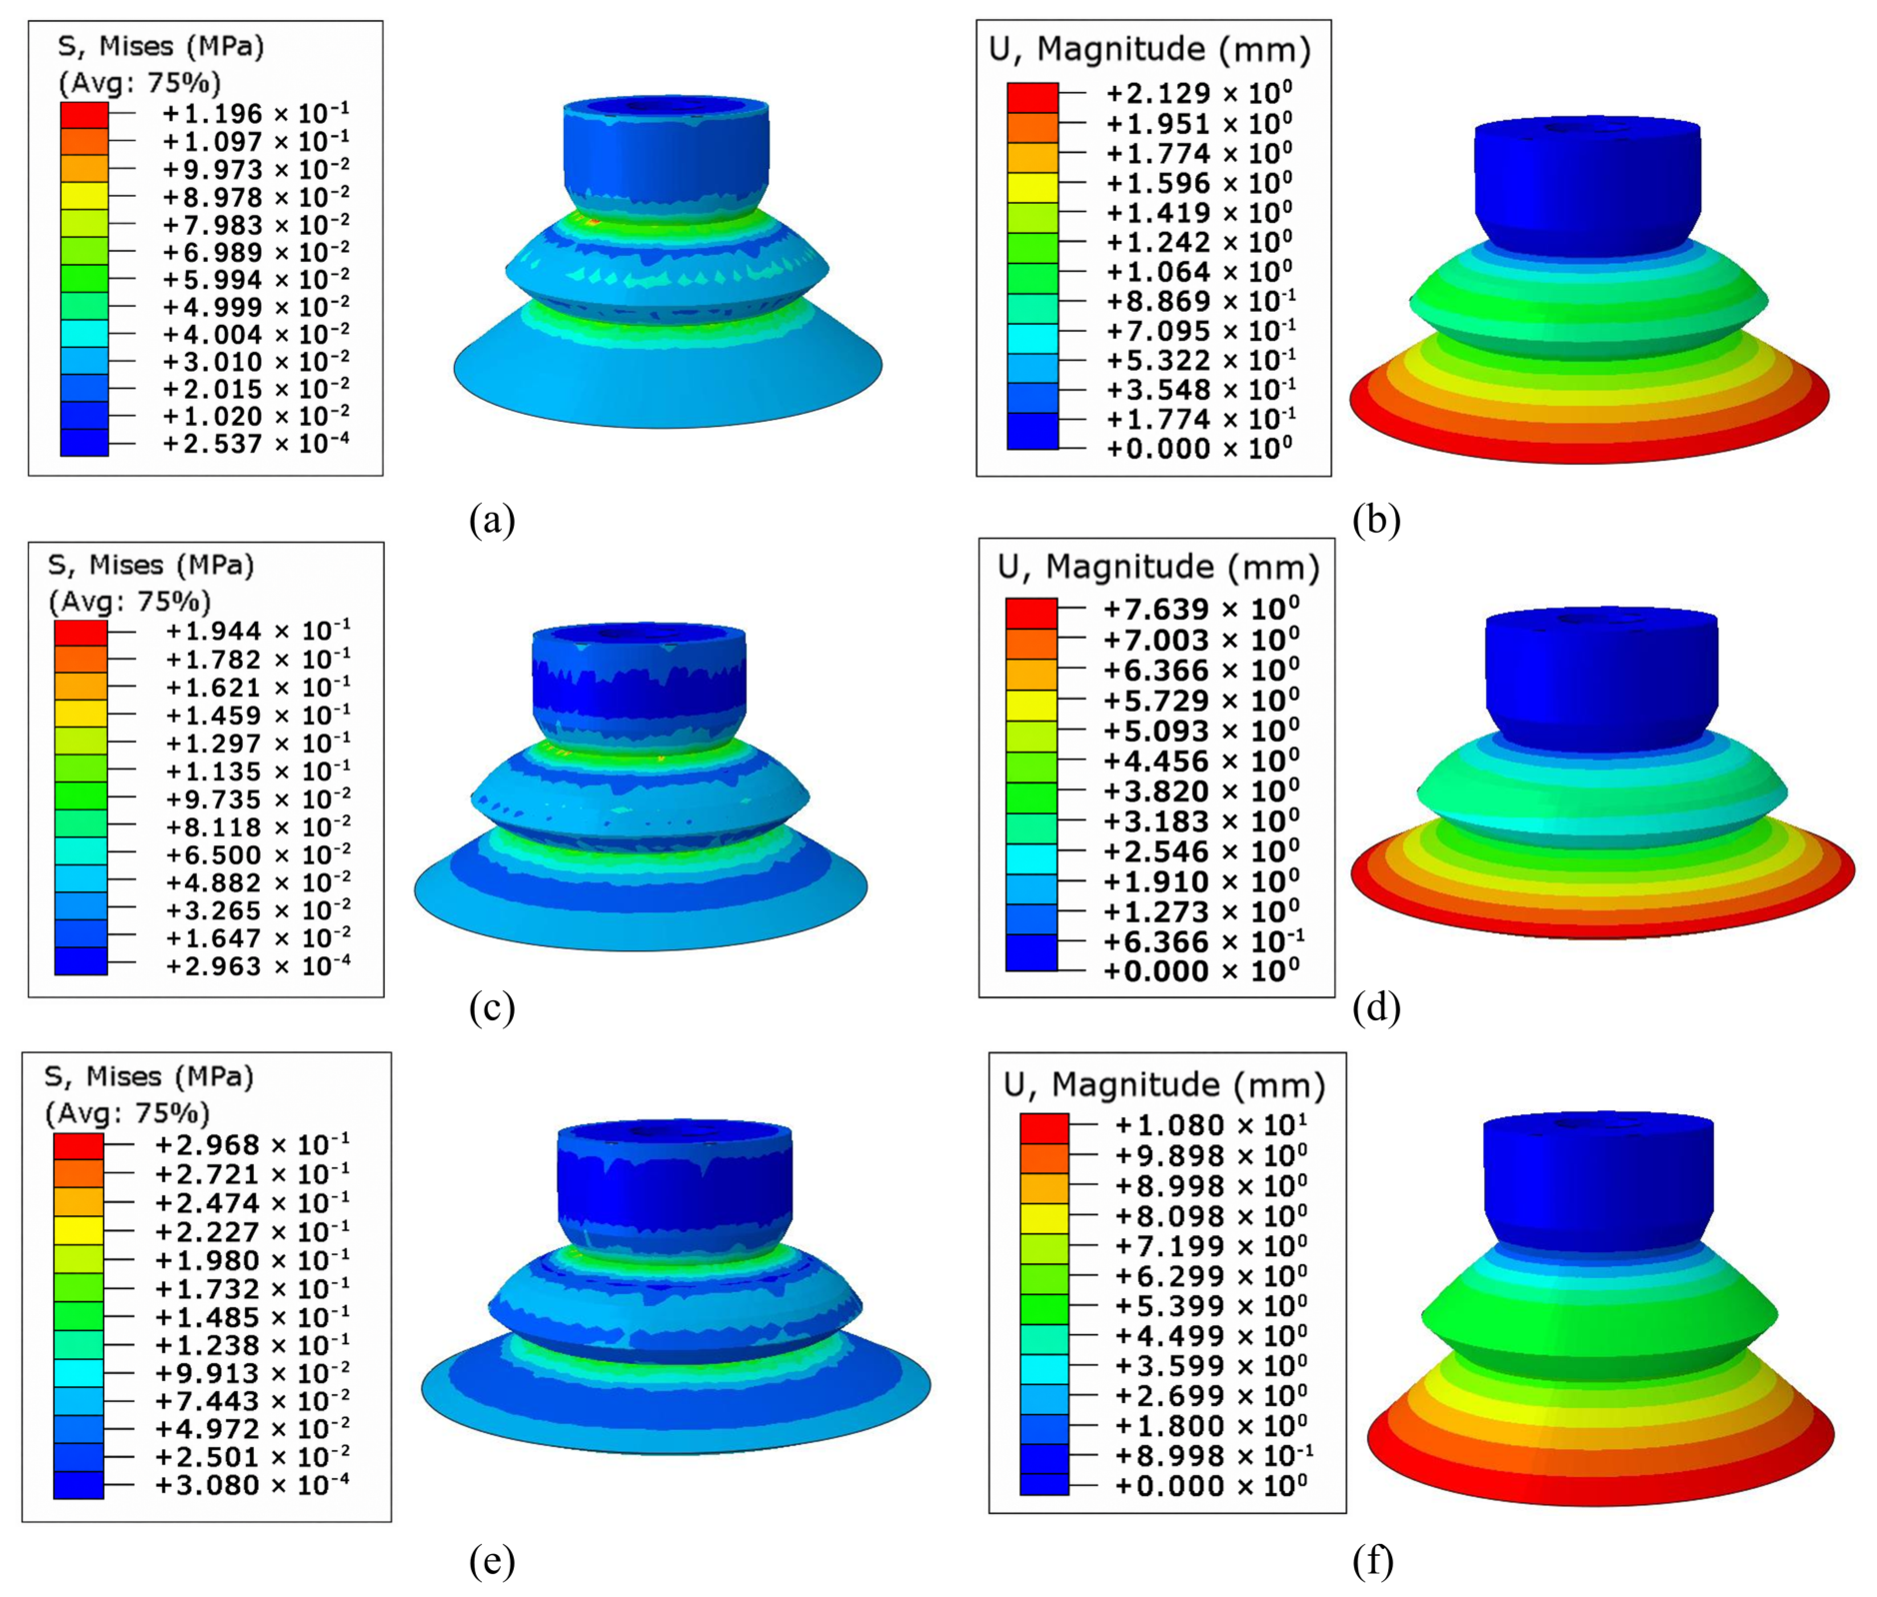
2.3. Finite Element Simulation
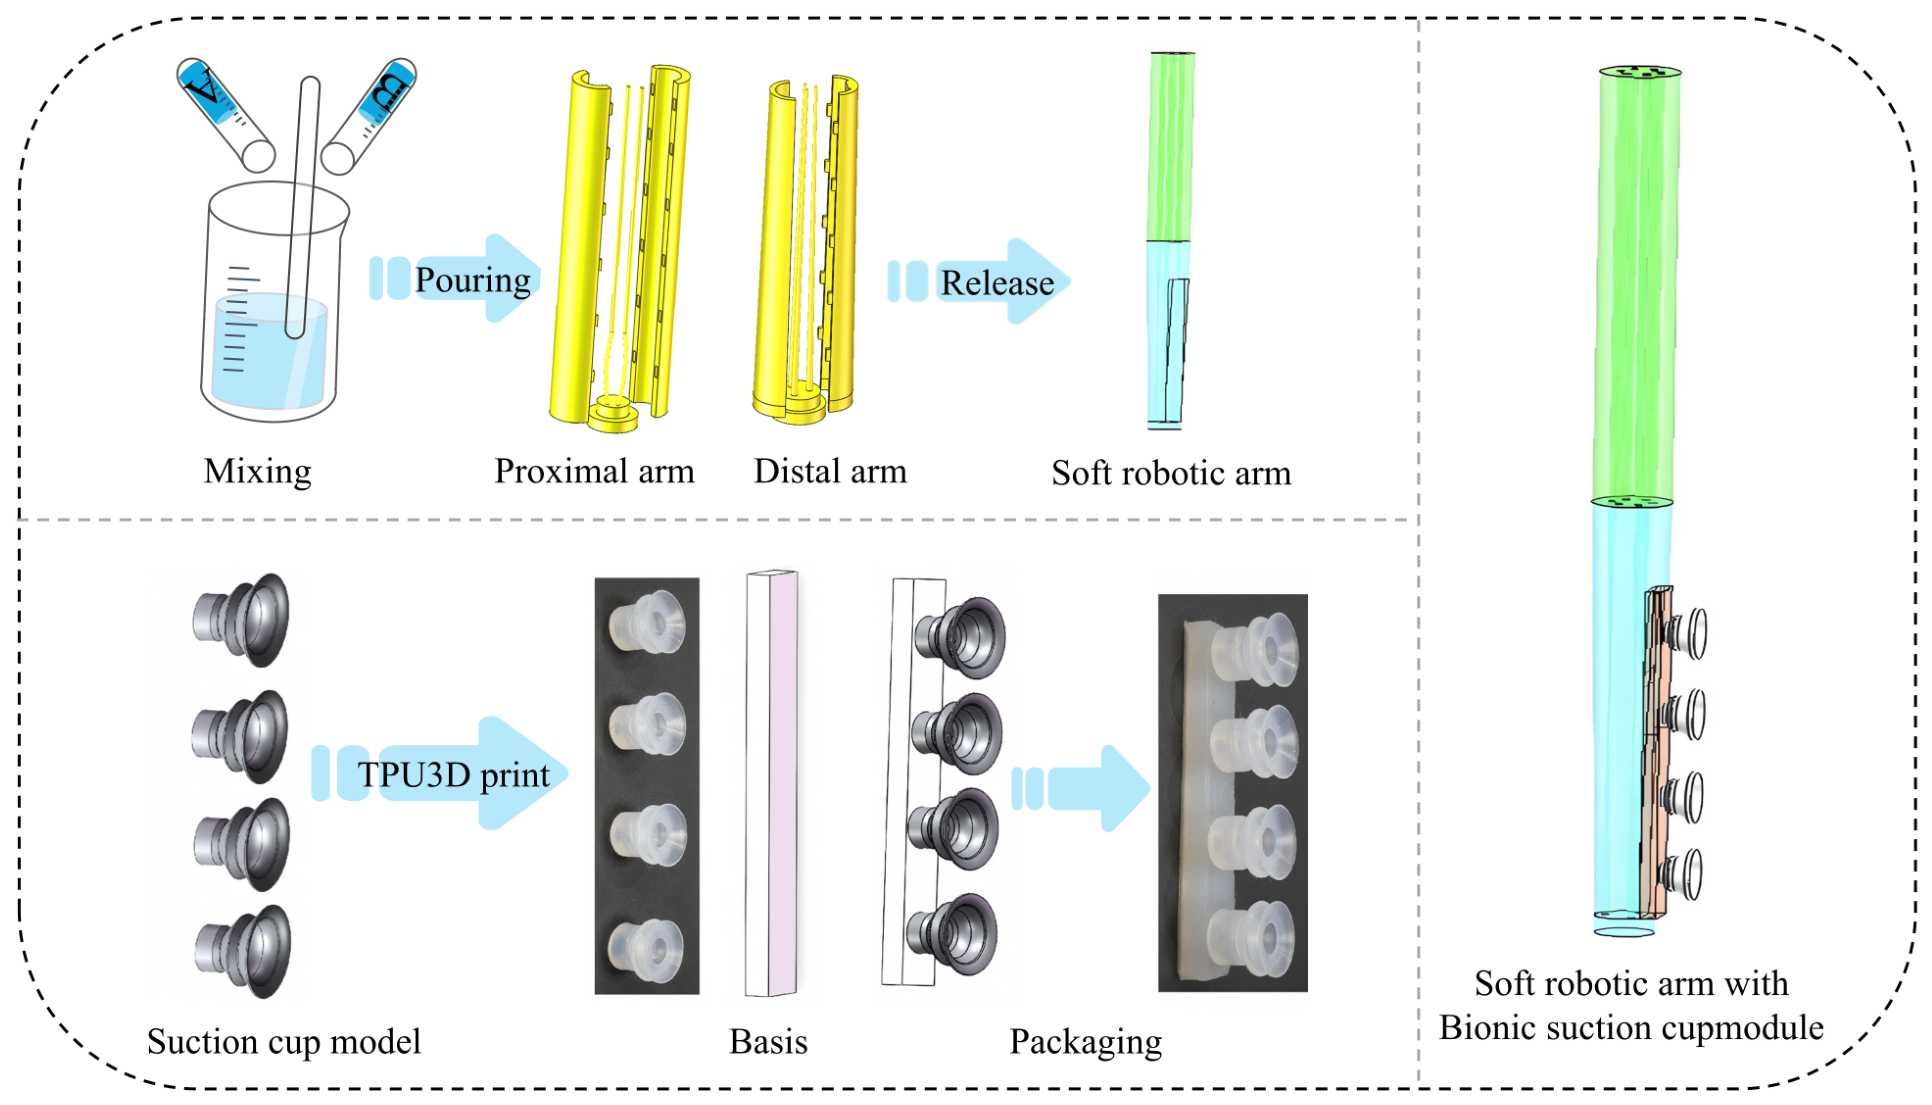
2.4. Fabrication
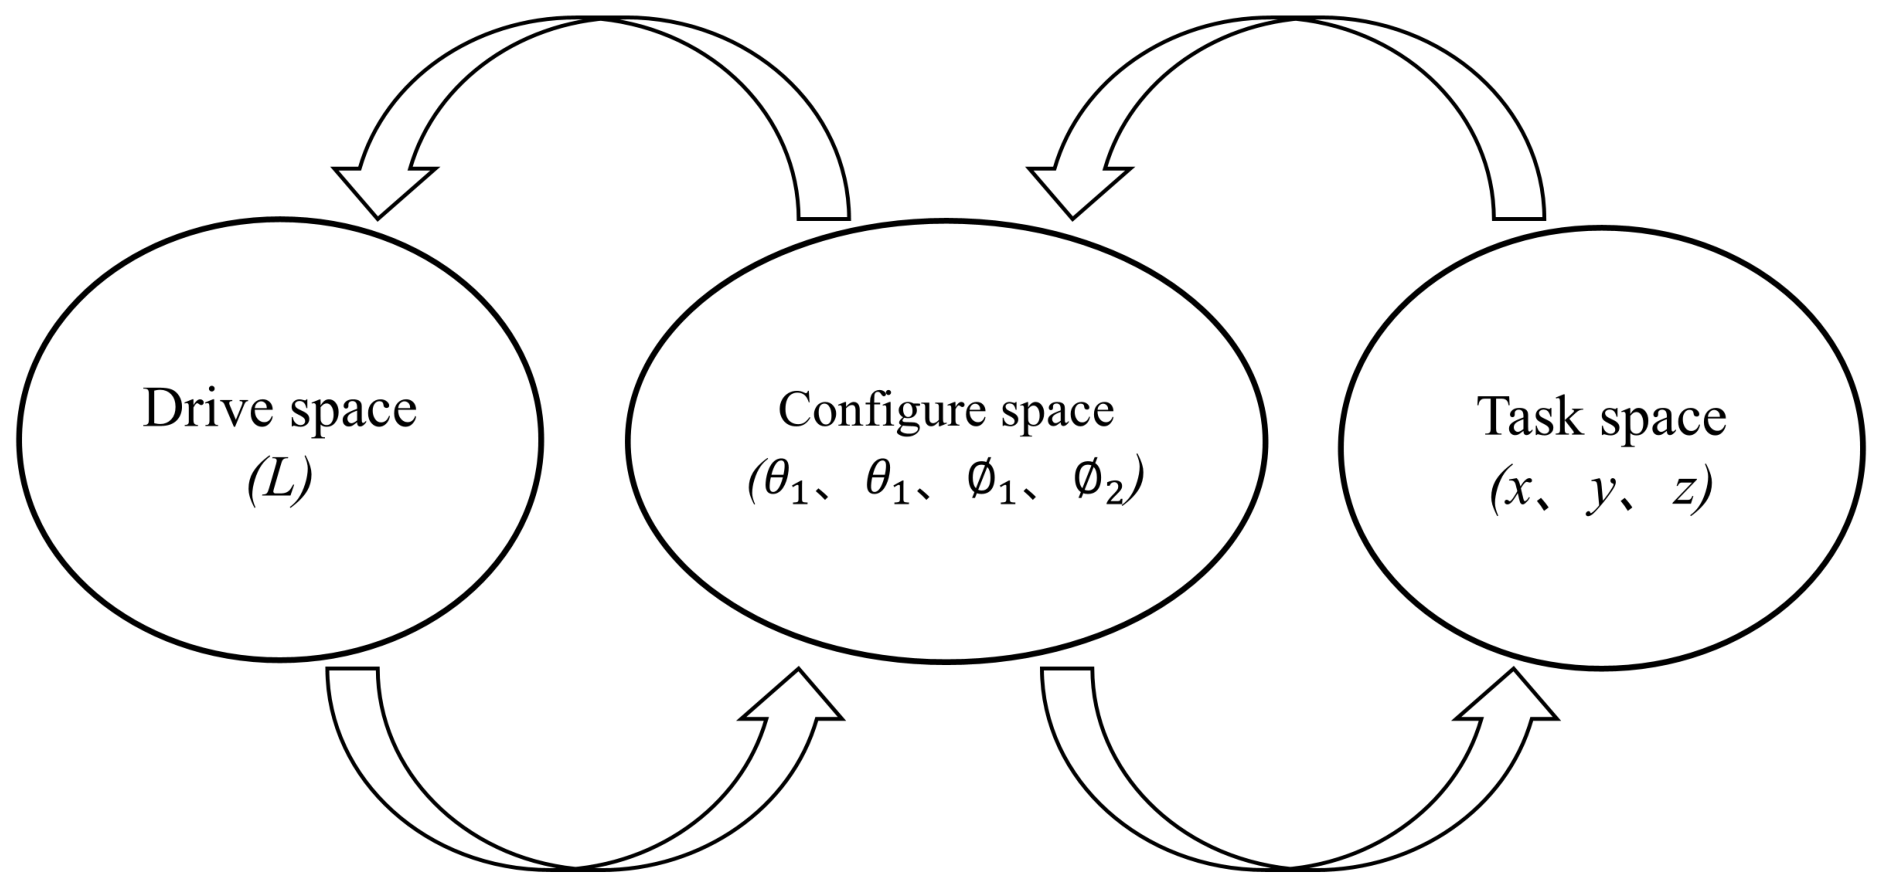
3. Kinematic Model and Workspace Analysis
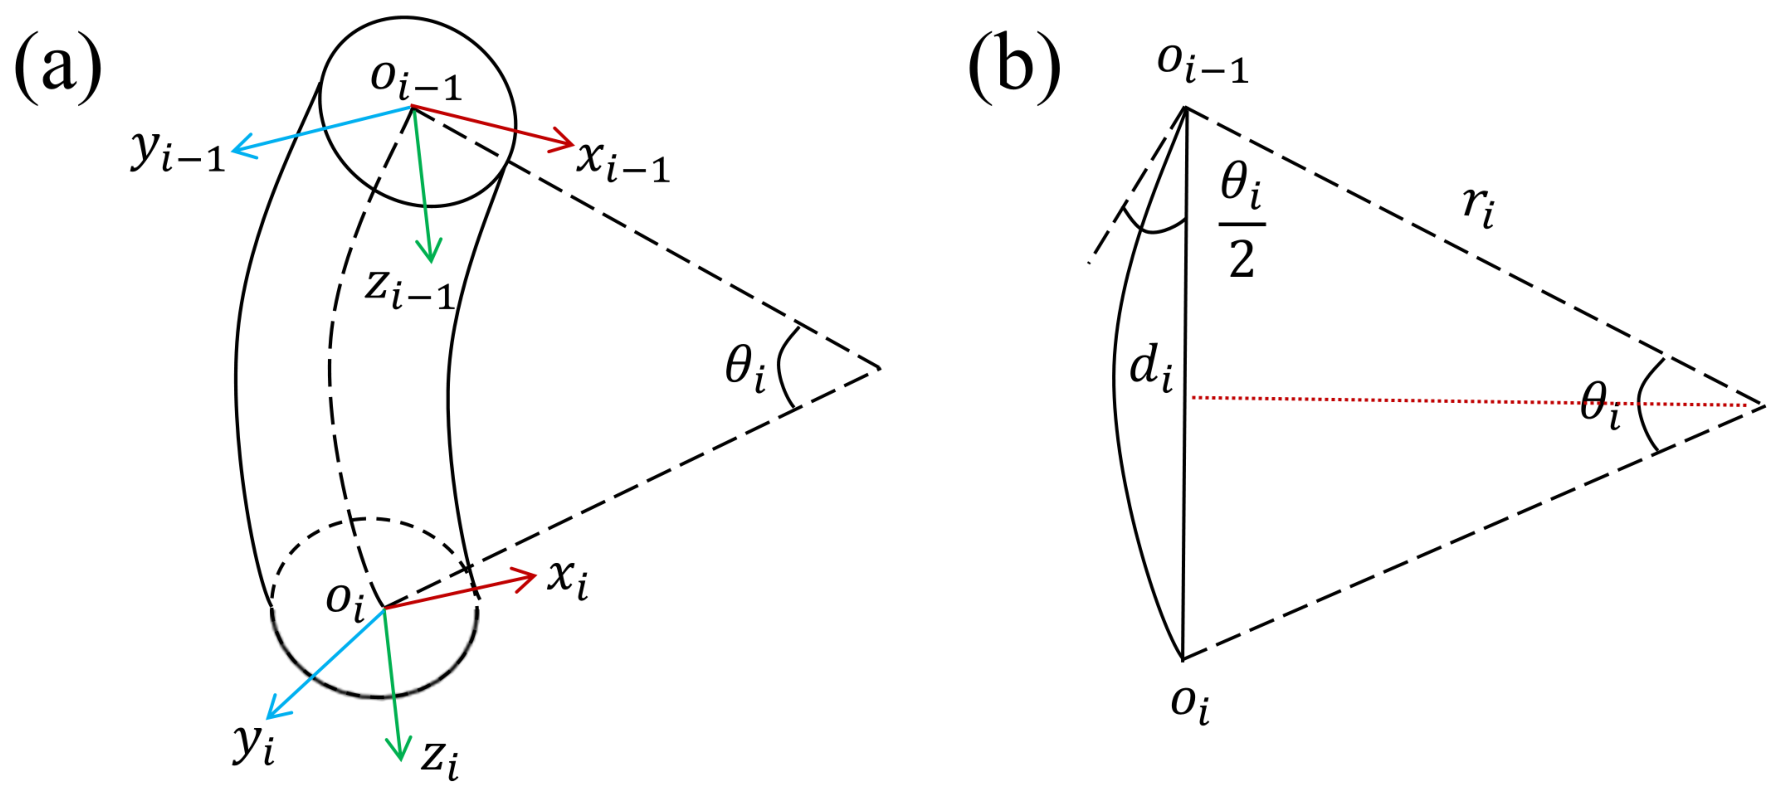
3.1. Piecewise Constant Curvature Model
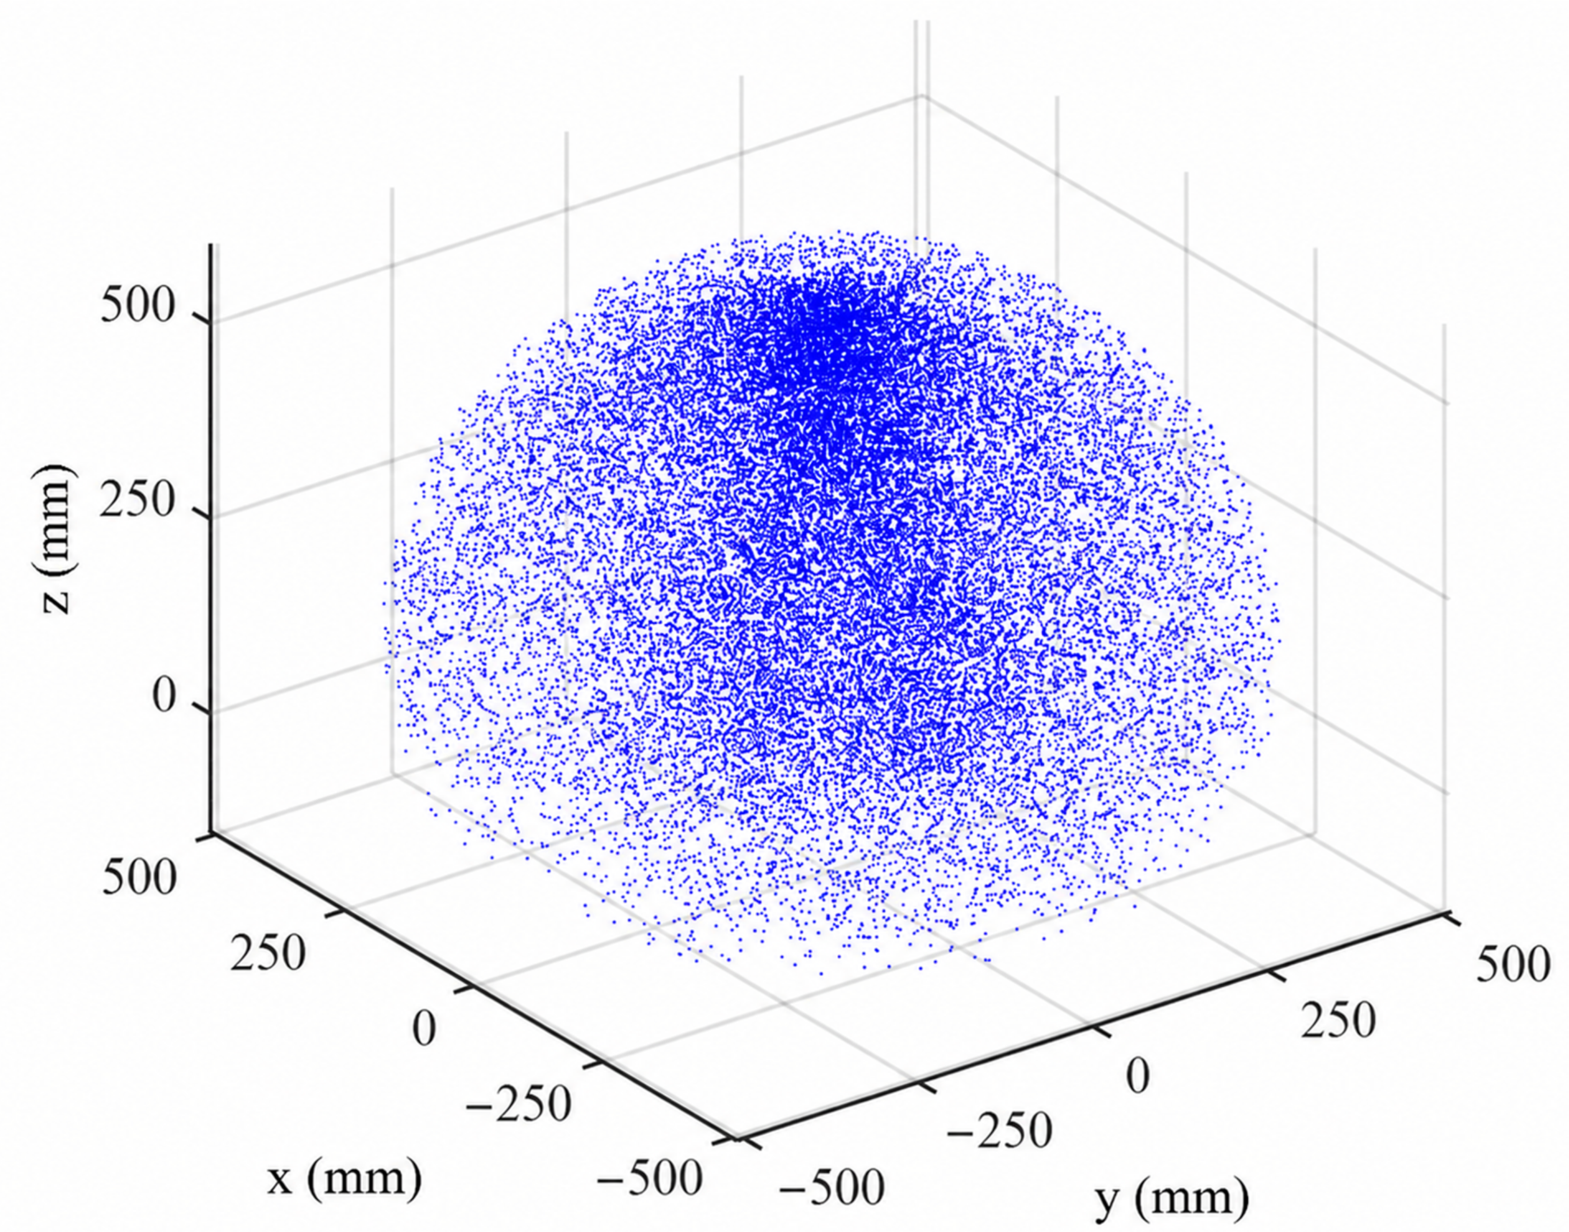
3.2. Workspace Analysis
4. Experimental Validation
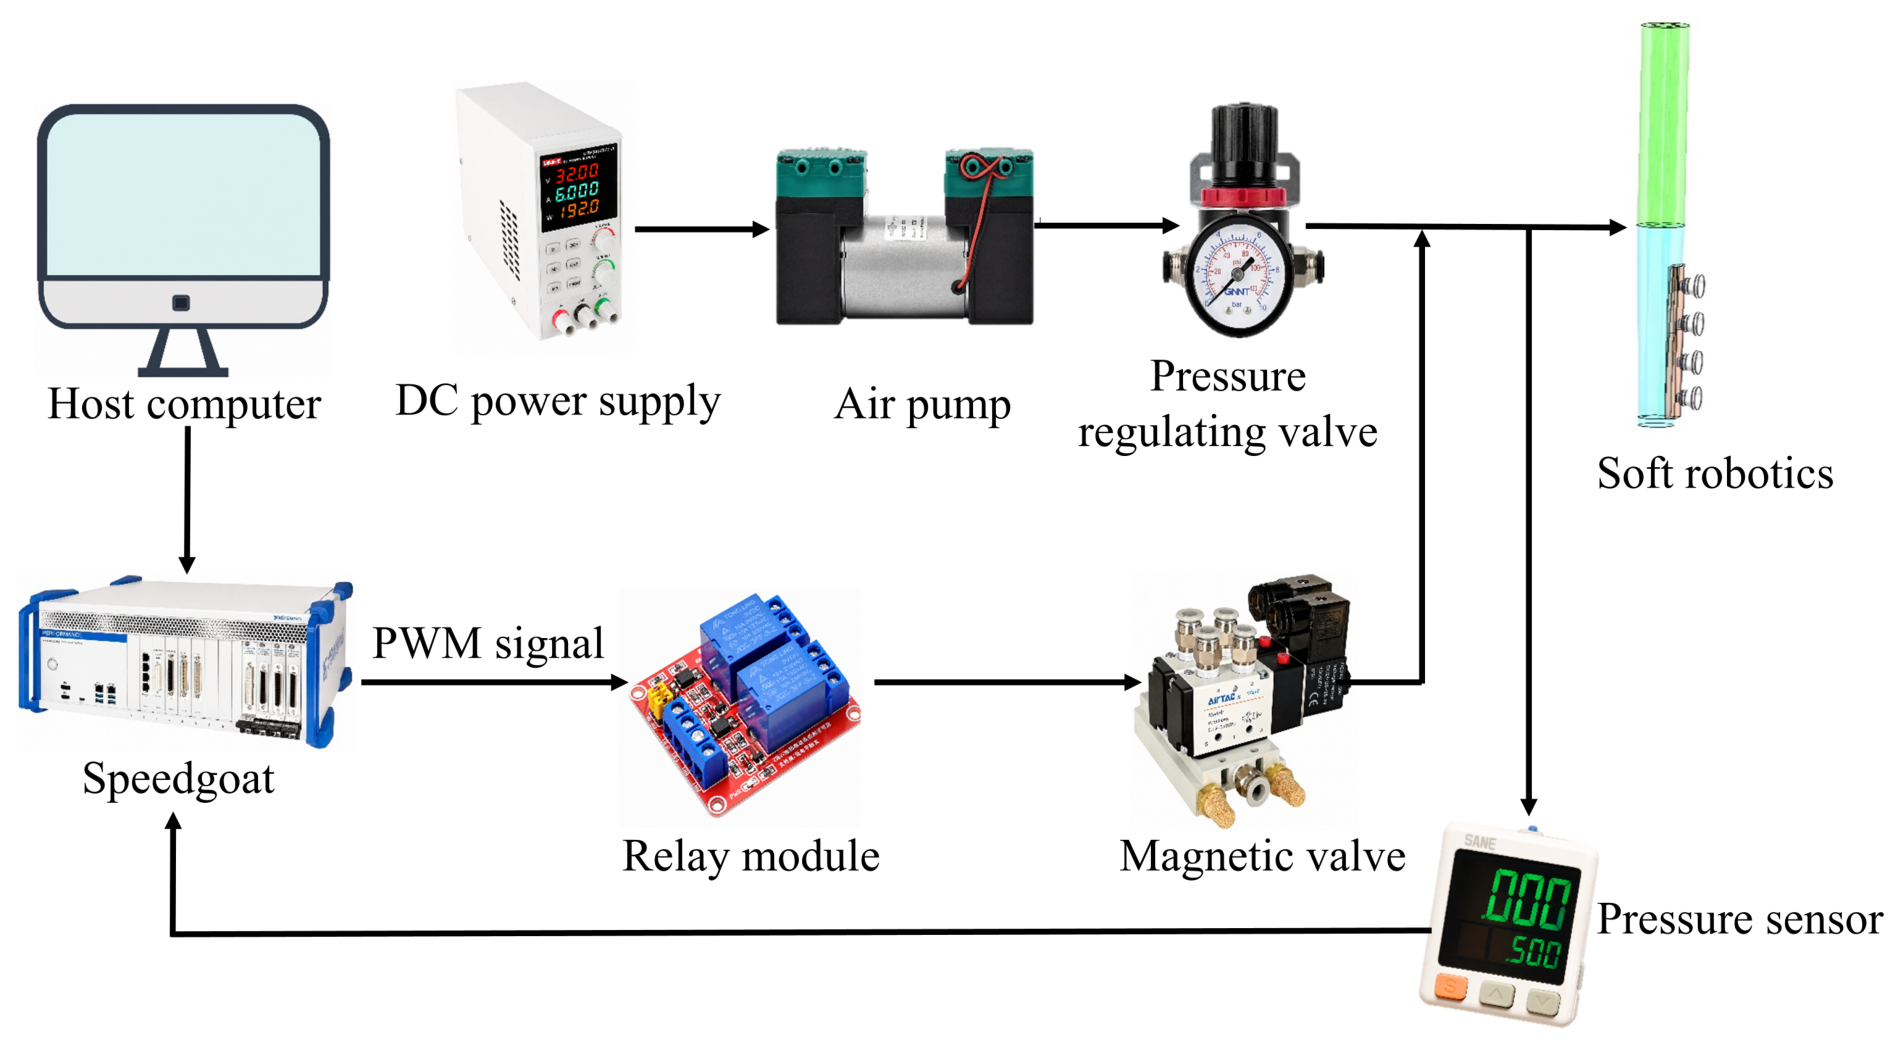
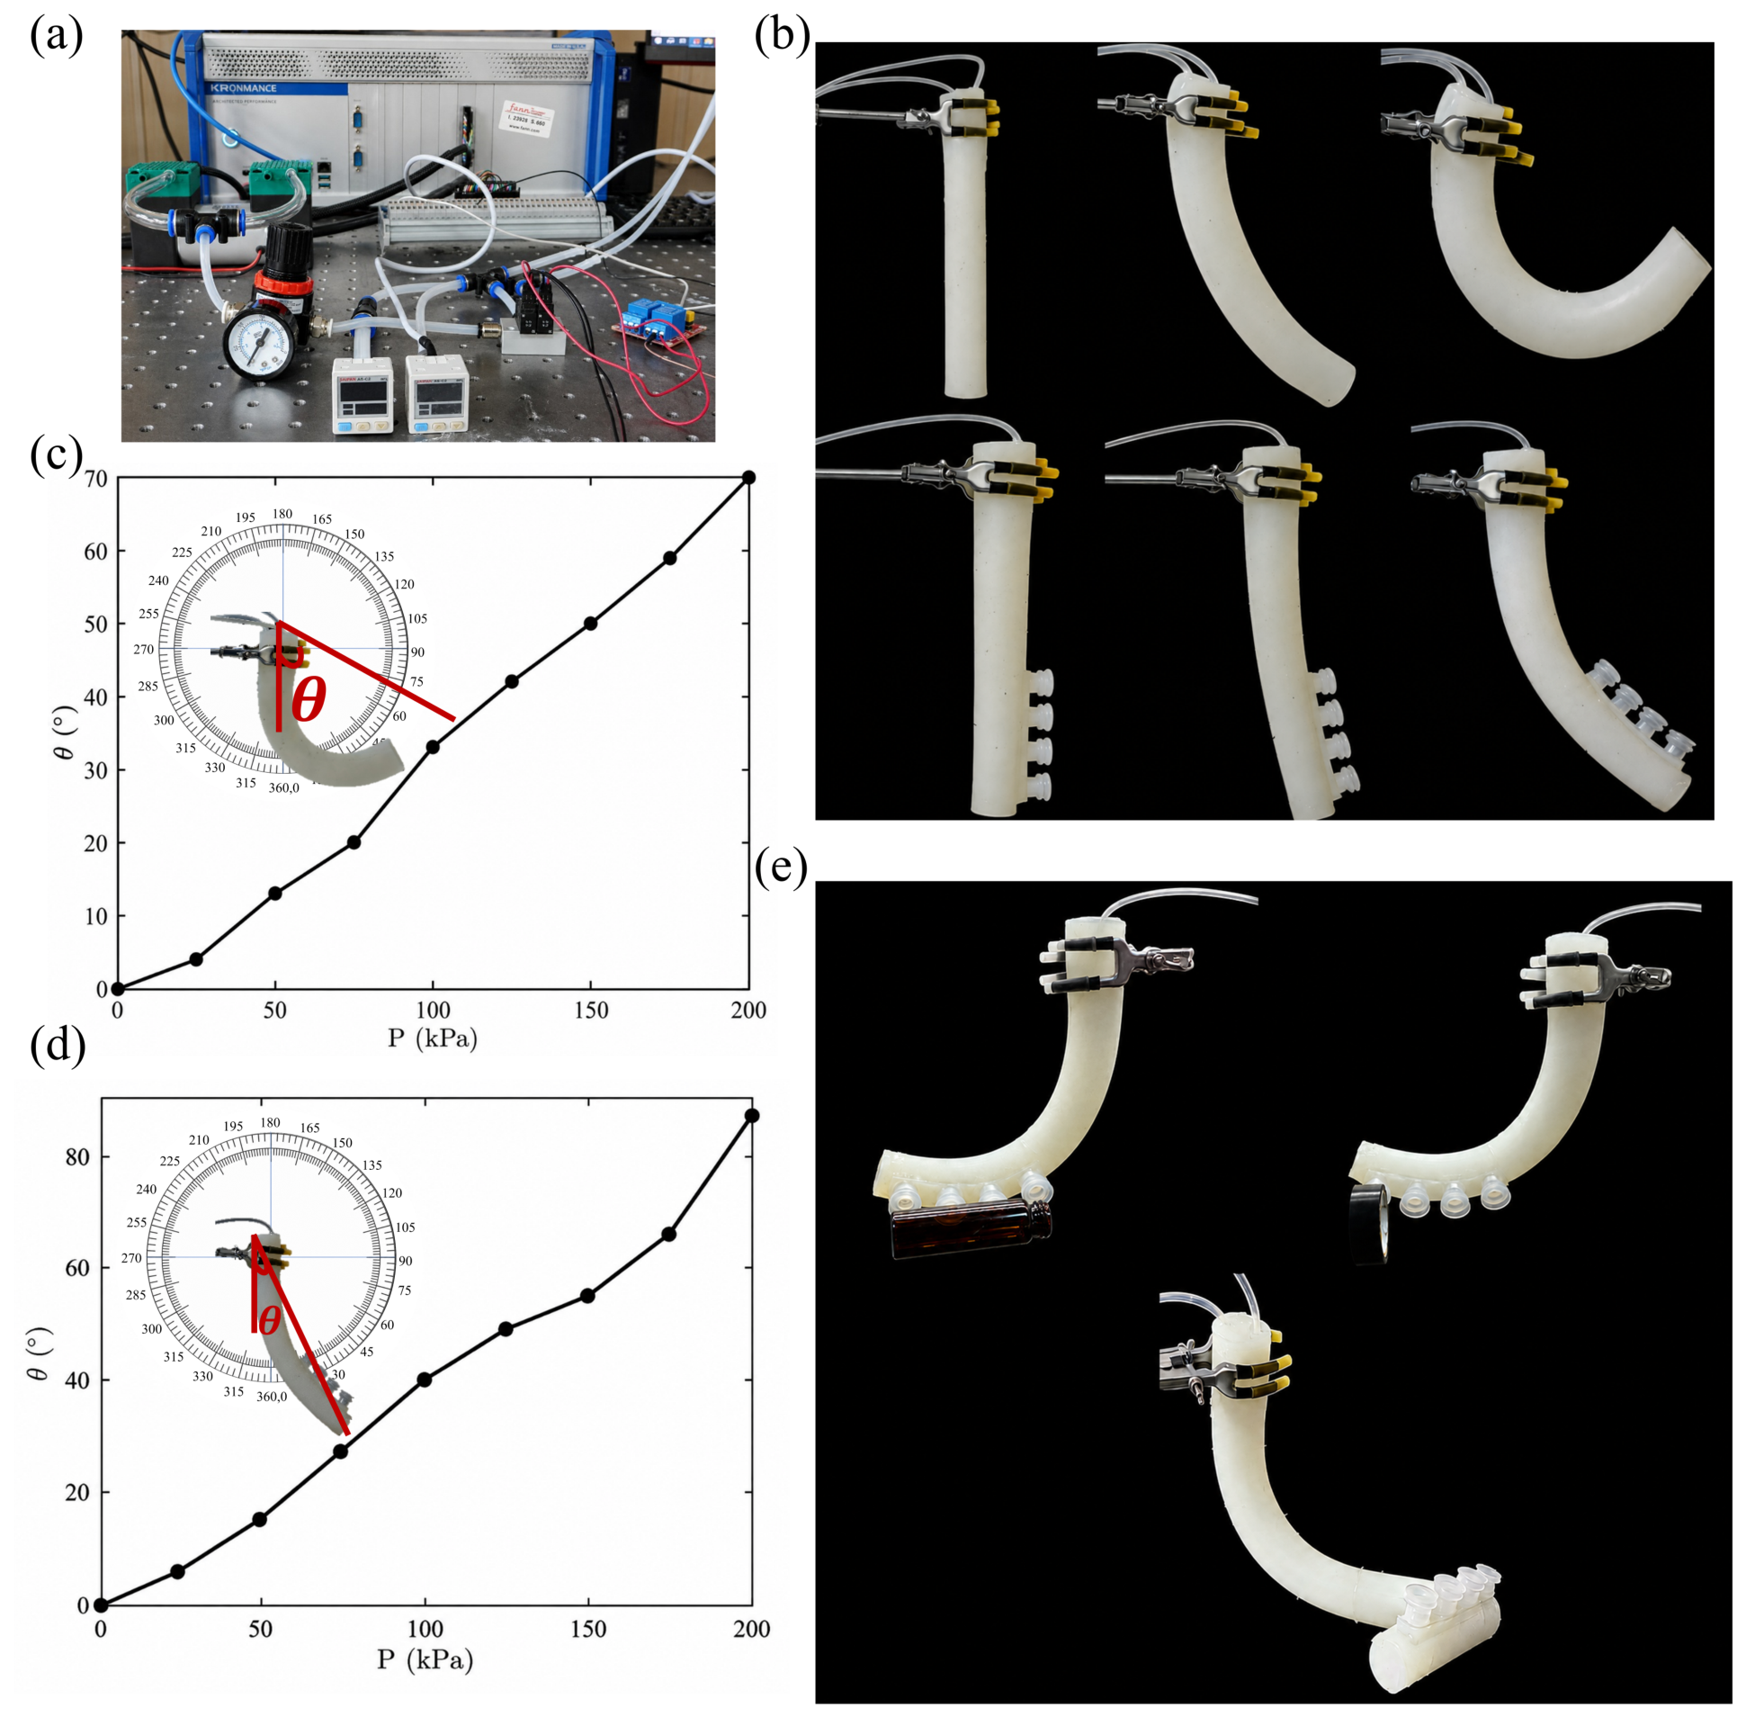
4.1. Experimental Platform
4.2. Bending and Manipulation Tests
5. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Rich, S.I.; Wood, R.J.; Majidi, C. Untethered soft robotics. Nat. Electron. 2018, 1, 102–112. [Google Scholar] [CrossRef] [Scilit]
- Rus, D.; Tolley, M.T. Design, fabrication and control of soft robots. Nature 2015, 521, 467–475. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Shah, D.S.; Powers, J.P.; Tilton, L.G.; Kriegman, S.; Bongard, J.; Kramer-Bottiglio, R. A soft robot that adapts to environments through shape change. Nat. Mach. Intell. 2021, 3, 51–59. [Google Scholar]
- Cianchetti, M.; Laschi, C.; Menciassi, A.; Dario, P. Biomedical applications of soft robotics. Nat. Rev. Mater. 2018, 3, 143–153. [Google Scholar] [CrossRef] [Scilit]
- Simons, M.F.; Digumarti, K.M.; Le, N.H.; Althoefer, K.; Nanayakkara, T. Ionic Glove: A soft smart wearable sensory feedback device for upper limb robotic prostheses. IEEE Robot. Autom. Lett. 2021, 6, 3311–3316. [Google Scholar] [CrossRef] [Scilit]
- Lin, M.; Hu, H.; Zhou, S.; Wang, Z. Soft wearable devices for deep-tissue sensing. Nat. Rev. Mater. 2022, 7, 850–869. [Google Scholar]
- Mosadegh, B.; Polygerinos, P.; Keplinger, C.; Wennstedt, S.; Shepherd, R.F.; Gupta, U.; Shim, J.; Bertoldi, K.; Walsh, C.J.; Whitesides, G.M. Pneumatic networks for soft robotics that actuate rapidly. Adv. Funct. Mater. 2014, 24, 2163–2170. [Google Scholar] [CrossRef] [Scilit]
- Nguyen, T.T.; Nguyen, D.Q.; Ho, V.A. Soft robot employing a series of pneumatic actuators and distributed balloons: Modeling, evaluation, and applications. IEEE Trans. Robot. 2024, 40, 3933–3949. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Z.; Long, Y.; Chen, G.; Wu, Q.; Wang, H.; Jiang, H. Soft and lightweight fabric enables powerful and high-range pneumatic actuation. Sci. Adv. 2023, 9, eadg1203. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Han, F.; Fei, L.; Zou, R.; Li, W.; Zhou, J.; Zhao, H. A restorable, variable stiffness pneumatic soft gripper based on jamming of strings of beads. IEEE Trans. Robot. 2023, 39, 4065–4077. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; Chen, Y.; Li, Y.; Chen, M.Z.Q.; Wei, Y. Bioinspired robotic fingers based on pneumatic actuator and 3D printing of smart material. Soft Robot. 2017, 4, 147–162. [Google Scholar] [PubMed]
- Cui, Y.; Liu, X.J.; Dong, X.; Chen, W. Enhancing the universality of a pneumatic gripper via continuously adjustable initial grasp postures. IEEE Trans. Robot. 2021, 37, 1604–1618. [Google Scholar]
- Zhang, Z.; Ni, X.; Gao, W.; Wang, X. Pneumatically controlled reconfigurable bistable bionic flower for robotic gripper. Soft Robot. 2022, 9, 657–668. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Jung, J.; Park, M.; Kim, D.; Park, Y.L. Optically Sensorized Elastomer Air Chamber for Proprioceptive Sensing of Soft Pneumatic Actuators. IEEE Robot. Autom. Lett. 2020, 5, 2333–2340. [Google Scholar] [CrossRef] [Scilit]
- Hao, Y.; Biswas, S.; Hawkes, E.W.; Wang, Y.; Okamura, A.M. A multimodal, enveloping soft gripper: Shape conformation, bioinspired adhesion, and expansion-driven suction. IEEE Trans. Robot. 2020, 37, 350–362. [Google Scholar]
- Stella, F.; Obayashi, N.; Della Santina, C.; Bicchi, A. An experimental validation of the polynomial curvature model: Identification and optimal control of a soft underwater tentacle. IEEE Robot. Autom. Lett. 2022, 7, 11410–11417. [Google Scholar]
- Ge, L.; Chen, F.; Wang, D.; Liu, H. Design, modeling, and evaluation of fabric-based pneumatic actuators for soft wearable assistive gloves. Soft Robot. 2020, 7, 583–596. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Hu, W.; Alici, G. Bioinspired three-dimensional-printed helical soft pneumatic actuators and their characterization. Soft Robot. 2020, 7, 267–282. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- de Payrebrune, K.M.; O’Reilly, O.M. On constitutive relations for a rod-based model of a pneu-net bending actuator. Extrem. Mech. Lett. 2016, 8, 38–46. [Google Scholar] [CrossRef] [Scilit]
- Jiang, C.; Wang, D.; Zhao, B.; Gu, G. Modeling and inverse design of bio-inspired multi-segment pneu-net soft manipulators for 3D trajectory motion. Appl. Phys. Rev. 2021, 8, 041406. [Google Scholar] [CrossRef] [Scilit]
- Wang, D.; Jiang, C.; Gu, G. Modeling and design of lattice-reinforced pneumatic soft robots. IEEE Trans. Robot. 2023, 40, 606–623. [Google Scholar] [CrossRef] [Scilit]
- Zhou, J.; Chen, S.; Wang, Z. A soft-robotic gripper with enhanced object adaptation and grasping reliability. IEEE Robot. Autom. Lett. 2017, 2, 2287–2293. [Google Scholar] [CrossRef] [Scilit]
- Ataka, A.; Abrar, T.; Putzu, F.; Althoefer, K. Model-based pose control of inflatable eversion robot with variable stiffness. IEEE Robot. Autom. Lett. 2020, 5, 3398–3405. [Google Scholar] [CrossRef] [Scilit]
- Ahmed, F.; Waqas, M.; Shaikh, B.; Khan, Z.H.; Bilal, M.; Iqbal, J. Multi-material bio-inspired soft octopus robot for underwater synchronous swimming. J. Bionic Eng. 2022, 19, 1229–1241. [Google Scholar] [CrossRef] [Scilit]
- Cianchetti, M.; Arienti, A.; Follador, M.; Ranzani, T.; Dario, P.; Menciassi, A. Design concept and validation of a robotic arm inspired by the octopus. Mater. Sci. Eng. C 2011, 31, 1230–1239. [Google Scholar] [CrossRef] [Scilit]
- Yue, T.; Lu, C.; Tang, K.; Wang, X.; Li, Y.; Wang, Z. Embodying soft robots with octopus-inspired hierarchical suction intelligence. Sci. Robot. 2025, 10, eadr4264. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Xiao, W.; Xie, C.; Xiao, Y.; Tang, K.; Wang, Z.; Hu, D.; Ding, R.; Jiao, Z. A new vacuum-powered soft bending actuator with programmable variable curvatures. Mater. Des. 2025, 250, 113641. [Google Scholar] [CrossRef] [Scilit]
- Mazzolai, B.; Mondini, A.; Tramacere, F.; Riccomi, G.; Sadeghi, A.; Giordano, G.; Del Dottore, E.; Scaccia, M.; Zampato, M.; Carminati, S. Octopus-inspired soft arm with suction cups for enhanced grasping tasks in confined environments. Adv. Intell. Syst. 2019, 1, 1900041. [Google Scholar] [CrossRef] [Scilit]
- Xie, Z.; Domel, A.G.; An, N.; Green, C.; Gong, Z.; Wang, T.; Knubben, E.M.; Weaver, J.C.; Bertoldi, K.; Wen, L. Octopus arm-inspired tapered soft actuators with suckers for improved grasping. Soft Robot. 2020, 7, 639–648. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Shi, Y.; Hou, X.; Na, Z.; Zhou, J.; Yu, N.; Liu, S.; Xin, L.; Gao, G.; Liu, Y. Bio-inspired attachment mechanism of Dynastes hercules: Vertical climbing for on-orbit assembly legged robots. J. Bionic Eng. 2024, 21, 137–148. [Google Scholar] [CrossRef] [Scilit]
- Wu, Z.; Wu, Q.; Du, F.; Zhao, Z.; Xiang, S.; Zhou, H.; Luo, Y. Design and control of dual-segment multi-wire driven bionic soft arm with integrated suction cups. Biomimetics 2025, 10, 133. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, C.; Zhang, J.; Yu, H.; Zhao, F.; Xu, Z.; Wei, X.; Wang, H.; Chen, X.; Ye, Z.-G.; Zhang, X.; et al. Deformation-adaptive pressure sensors based on multi-level discrete sensing arrays for morphing electronics and human–machine interaction. npj Flex. Electron. 2026, 10, 21. [Google Scholar] [CrossRef] [Scilit]
- Yeoh, O.H. Some forms of the strain energy function for rubber. Rubber Chem. Technol. 1993, 66, 754–771. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.; Hu, C.; Dai, Y.; Huang, W.; Li, H.; Lan, Y. Soft array surface-changing compound eye. Sensors 2021, 21, 8298. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, Y.; Luo, W.; Huang, J.; Peng, C.; Wang, H.; Yuan, C.; Chen, G.; Zeng, B.; Dai, L. Simplification of hyperelastic constitutive model and finite element analysis of thermoplastic polyurethane elastomers. Macromol. Theory Simul. 2020, 29, 2000009. [Google Scholar] [CrossRef] [Scilit]






| Reference | Arm Architecture and Actuation | Distal Interface | Distinguishing Design Feature |
|---|---|---|---|
| Mazzolai et al. [28] | Octopus-inspired soft arm | Suction cups | Integration of a compliant arm and suction cups for grasping in confined environments. |
| Xie et al. [29] | Tapered pneumatic soft actuator | Suckers | Tapered geometry and sucker-assisted grasping. |
| Wu et al. [31] | Dual-segment, multi-wire-driven soft arm | Integrated suction cups | Cable-driven dual-segment actuation with integrated cups. |
| This work | Cylindrical proximal segment and tapered distal segment; each has three pneumatic chambers at 120° | Passive, vacuum-free TPU cup array | Separate pneumatic actuation of the proximal and distal segments for global posture adjustment and local contact adjustment. |
| Item | Setting |
|---|---|
| Software and analysis | Abaqus; static large-deformation analysis; mm–N–s–MPa unit system. |
| Arm discretization | C3D10H quadratic hybrid tetrahedra; global seed 6 mm; 24,619 nodes; 15,889 elements. |
| Arm boundary and load | Proximal end fully fixed; one proximal actuation-chamber inner wall pressurized at 50, 100, 150, or 200 kPa; the other two proximal actuation chambers at zero gauge pressure. |
| Silicone model | Third-order Yeoh model: MPa, MPa, MPa, MPa−1, , kg m−3 [33,34]. |
| Cup model | Third-order Yeoh model: MPa, MPa, MPa, MPa−1, , kg m−3. The TPU properties were represented by a literature-informed parameter set for comparable 85A polyether TPU [35]. |
| Cup loading scope | Equivalent pressure differences of 10, 25, and 50 kPa applied to the inner cavity surfaces as parametric post-compression sealing conditions. |
| Pressure (kPa) | Maximum Displacement (mm) | Maximum von Mises Stress (MPa) |
|---|---|---|
| 50 | 198 | 8.60 |
| 100 | 229 | 10.07 |
| 150 | 271 | 15.51 |
| 200 | 302 | 18.42 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Mei, S.; Ma, T.; Yin, R.; Liu, C.; Chen, H. Octopus-Inspired Modular Two-Segment Pneumatic Soft Manipulator with Passive Suction Cups. Biomimetics 2026, 11, 558. https://doi.org/10.3390/biomimetics11080558
Mei S, Ma T, Yin R, Liu C, Chen H. Octopus-Inspired Modular Two-Segment Pneumatic Soft Manipulator with Passive Suction Cups. Biomimetics. 2026; 11(8):558. https://doi.org/10.3390/biomimetics11080558
Chicago/Turabian StyleMei, Siyu, Tongtong Ma, Rensong Yin, Chong Liu, and Hui Chen. 2026. "Octopus-Inspired Modular Two-Segment Pneumatic Soft Manipulator with Passive Suction Cups" Biomimetics 11, no. 8: 558. https://doi.org/10.3390/biomimetics11080558
APA StyleMei, S., Ma, T., Yin, R., Liu, C., & Chen, H. (2026). Octopus-Inspired Modular Two-Segment Pneumatic Soft Manipulator with Passive Suction Cups. Biomimetics, 11(8), 558. https://doi.org/10.3390/biomimetics11080558