Article

Composite Objective Optimization of Finger Length Under Performance Trade-Offs and Constraints

1
Center for X-Mechanics, Zhejiang University, Hangzhou 310012, China
2
State Key Laboratory of Fluid Power and Mechatronic System, Zhejiang University, Hangzhou 310012, China
3
ZJU-Hangzhou Global Scientific and Technological Innovation Center, Zhejiang University, Hangzhou 311200, China
*
Authors to whom correspondence should be addressed.
Biomimetics 2026, 11(8), 529; https://doi.org/10.3390/biomimetics11080529

Submission received: 6 May 2026 / Revised: 2 July 2026 / Accepted: 21 July 2026 / Published: 30 July 2026
(This article belongs to the Special Issue Bio-Inspired Robots: Design and Application)

Abstract

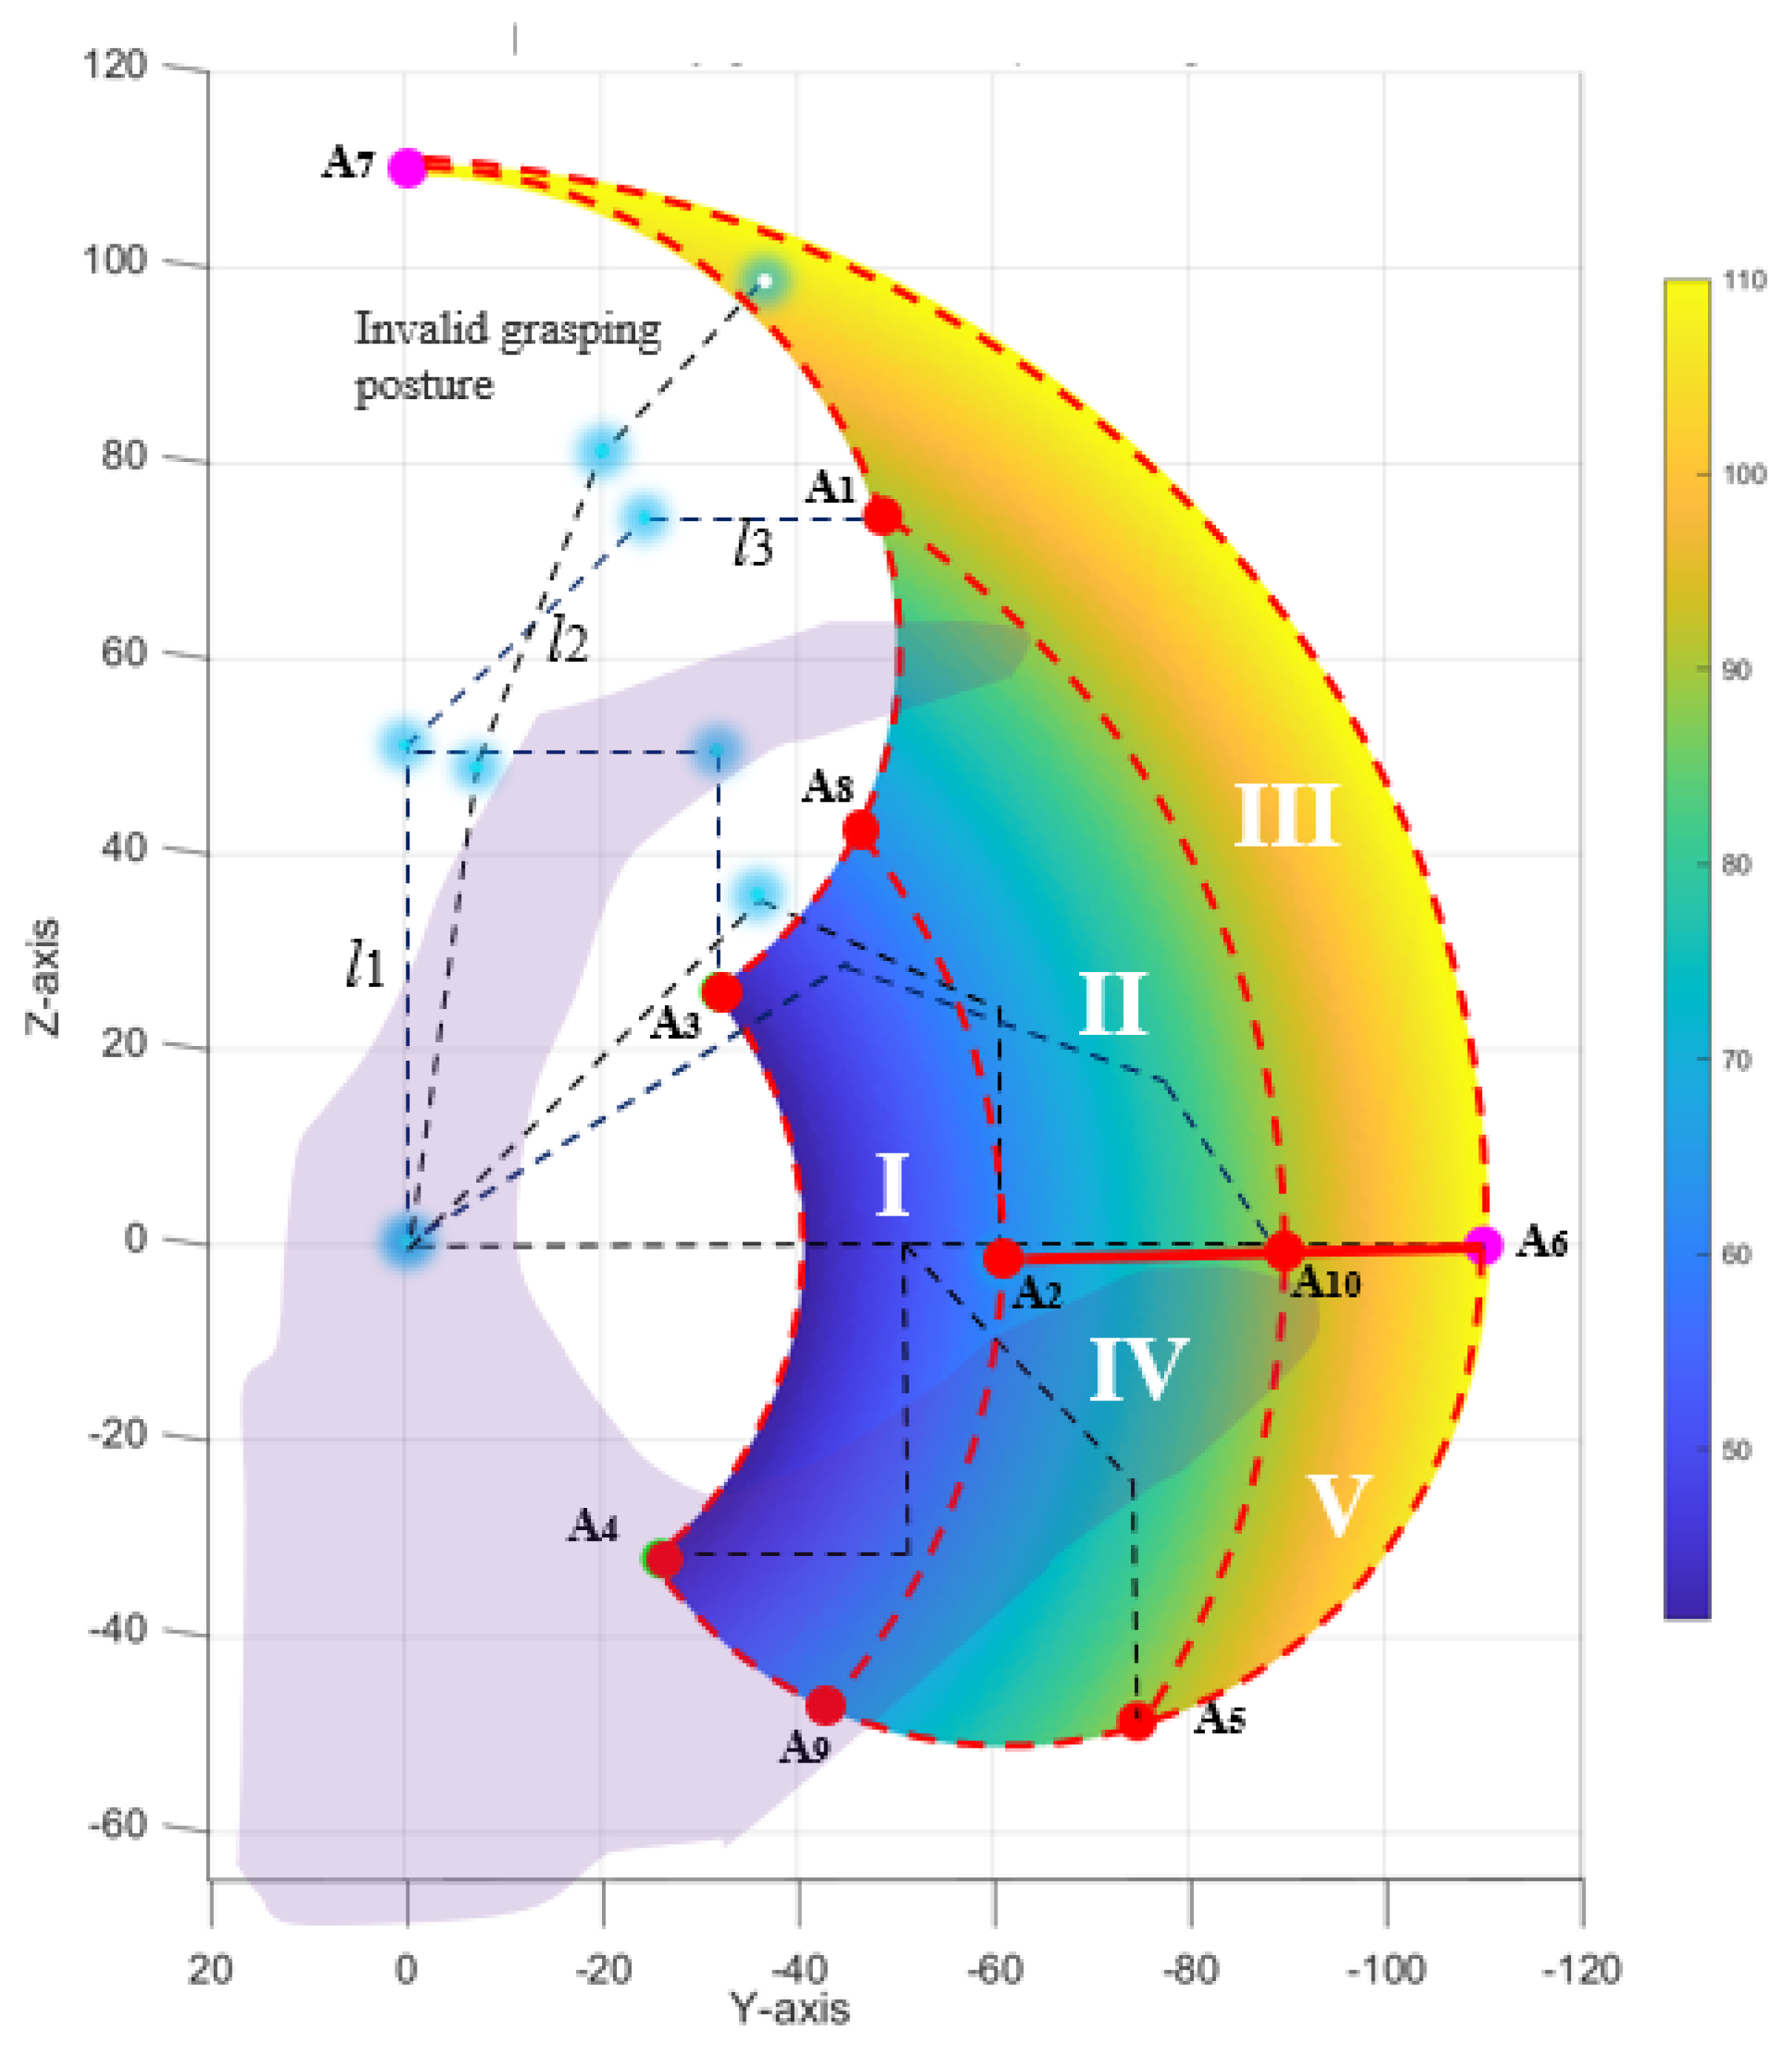
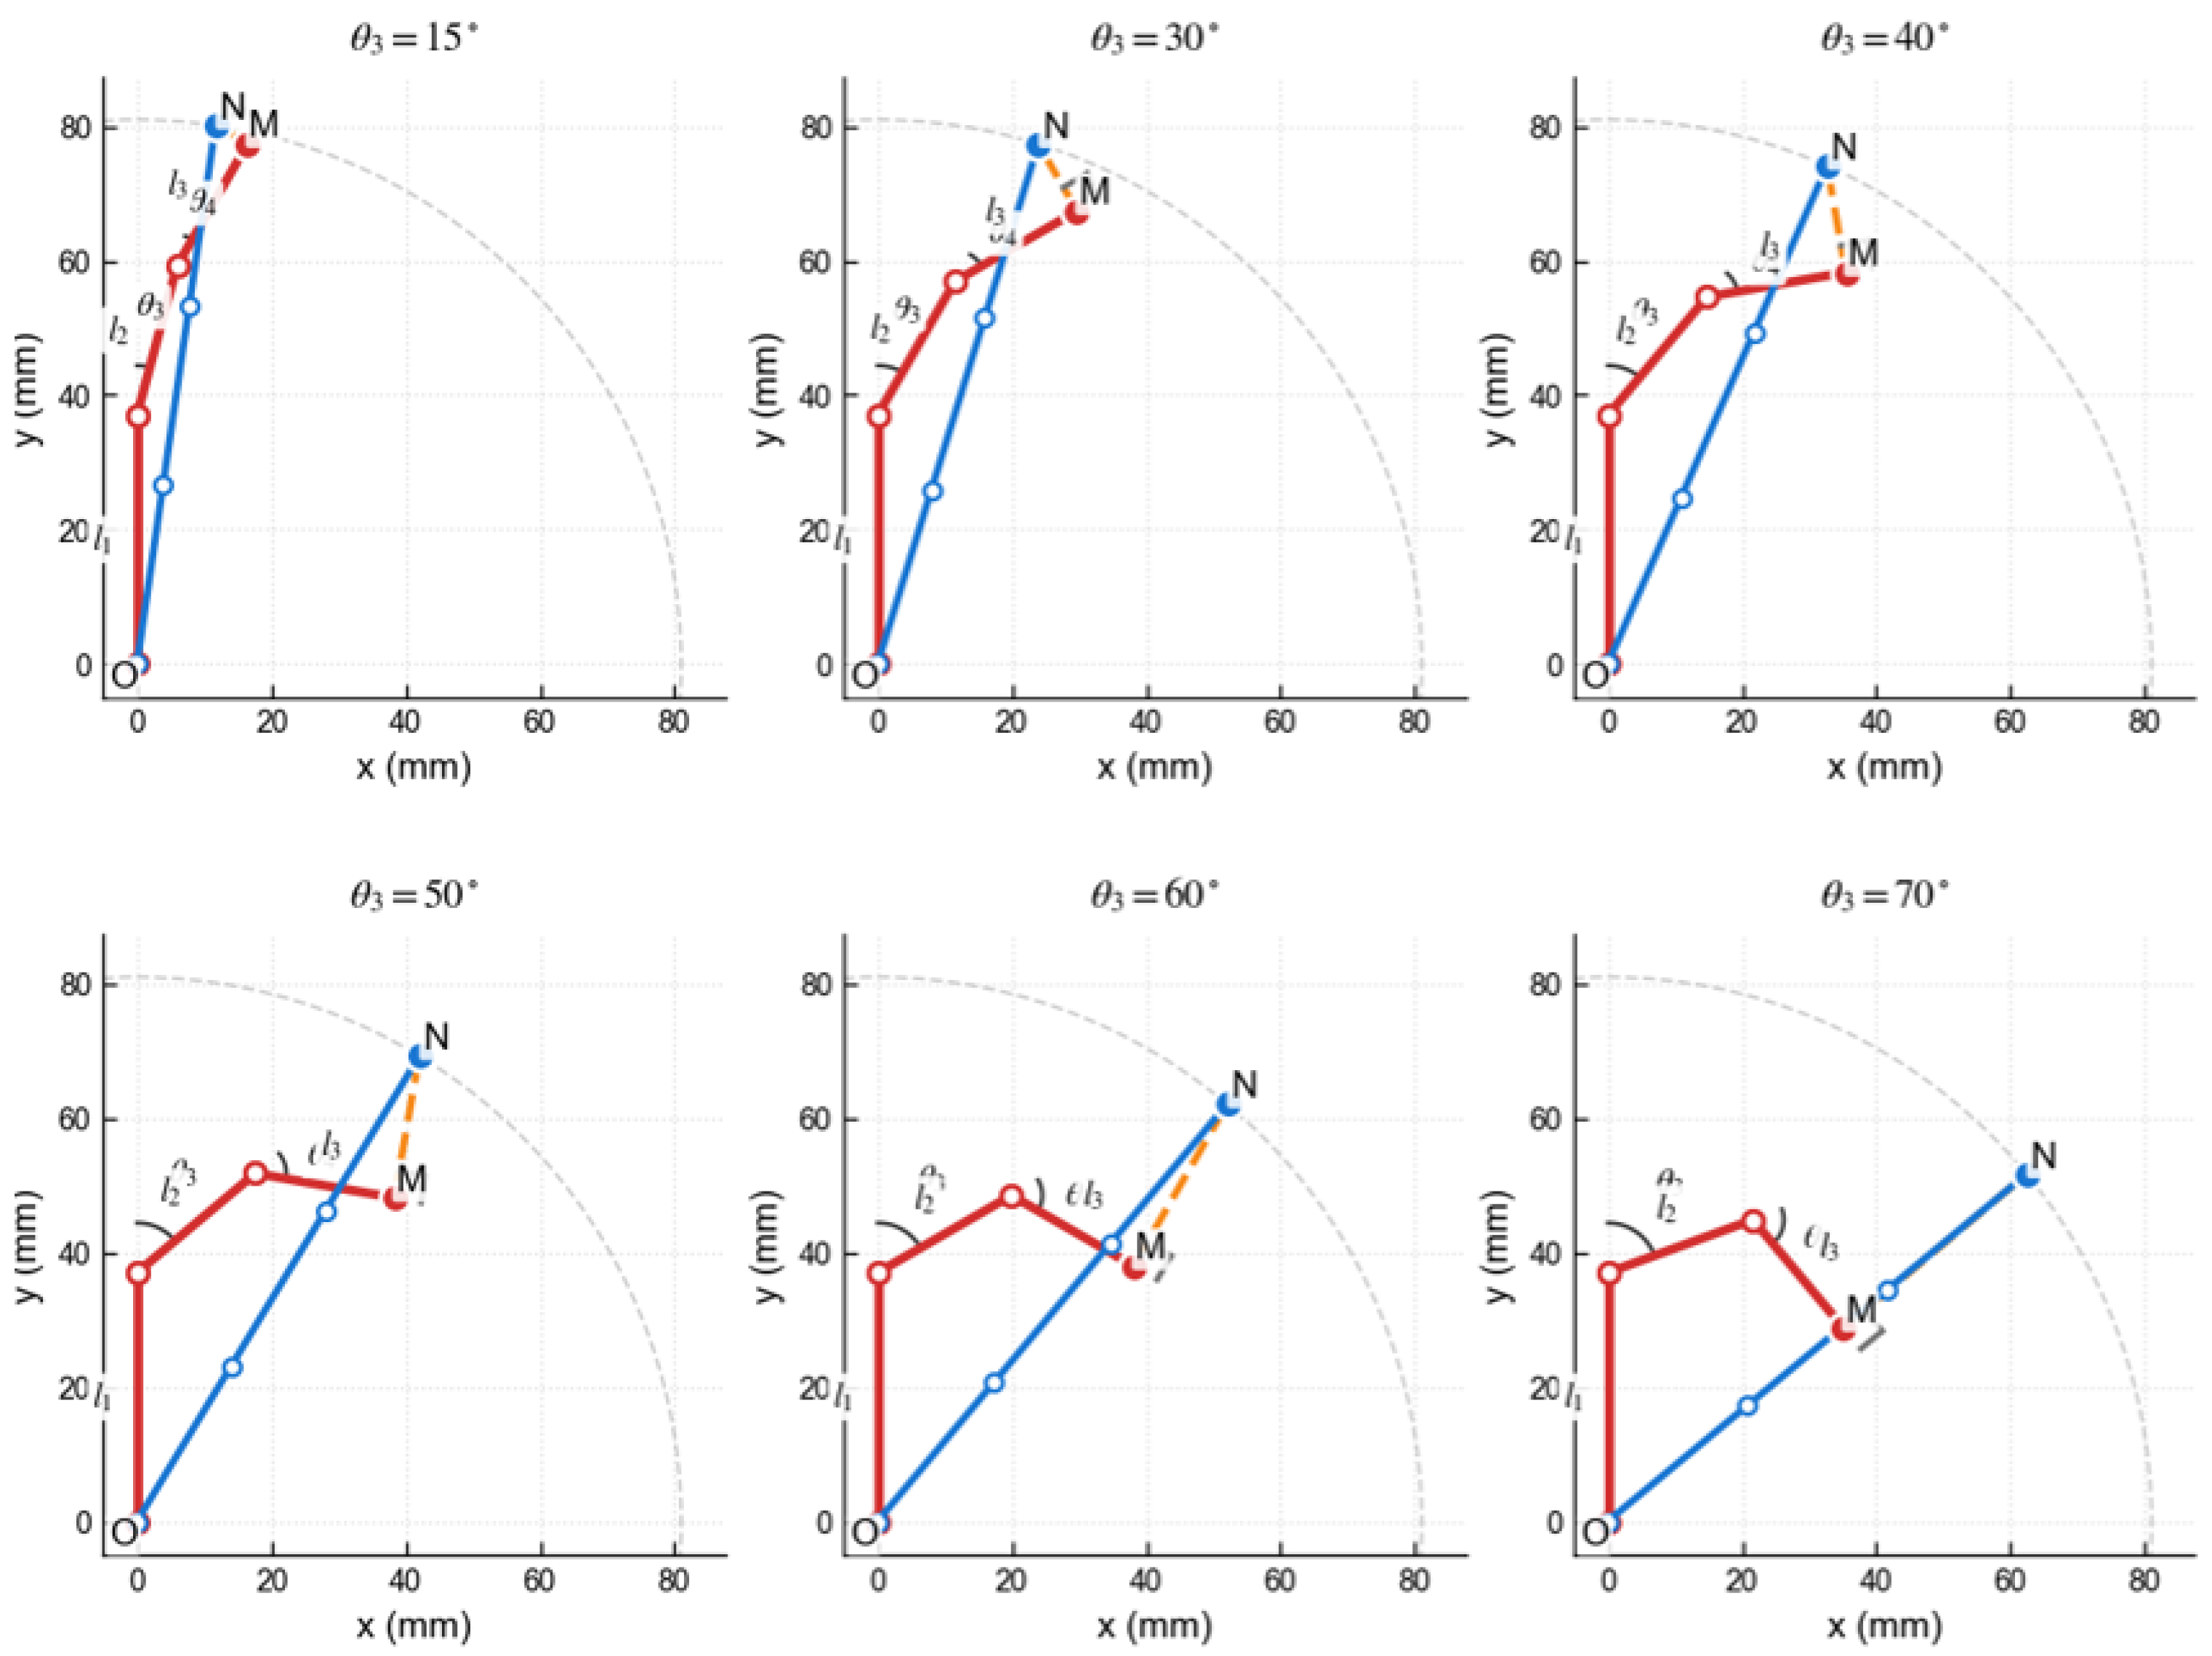
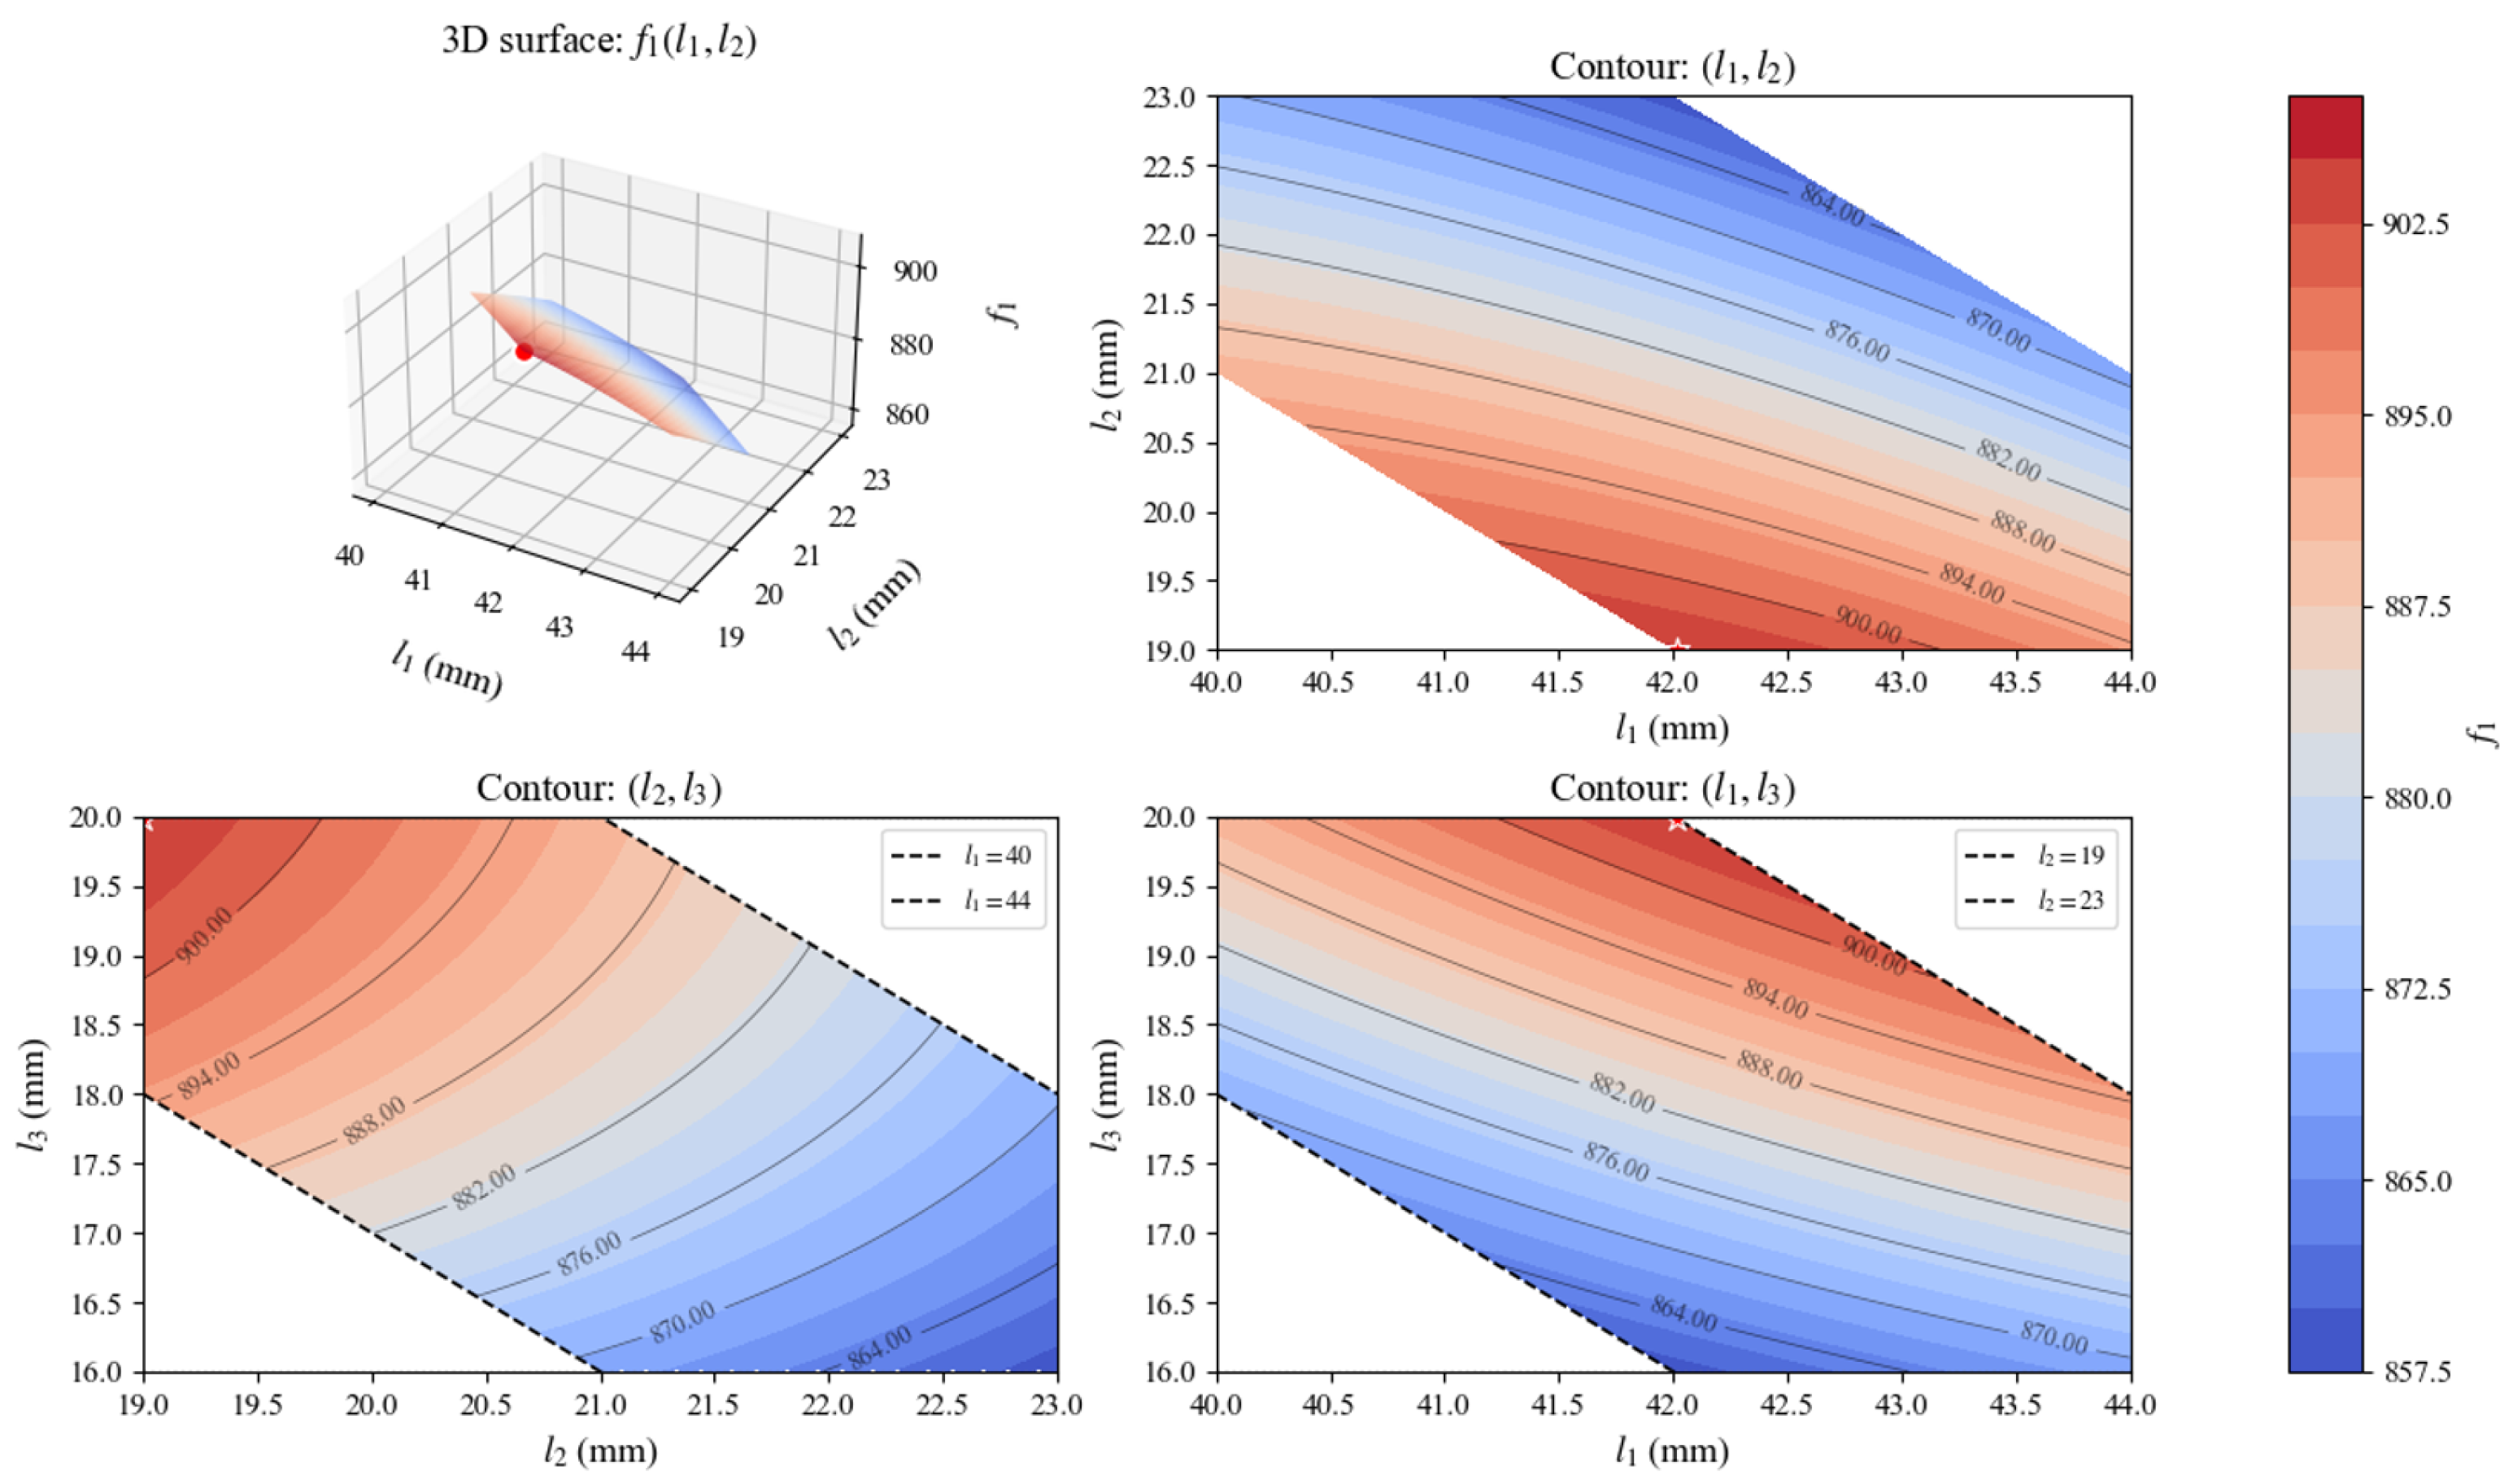
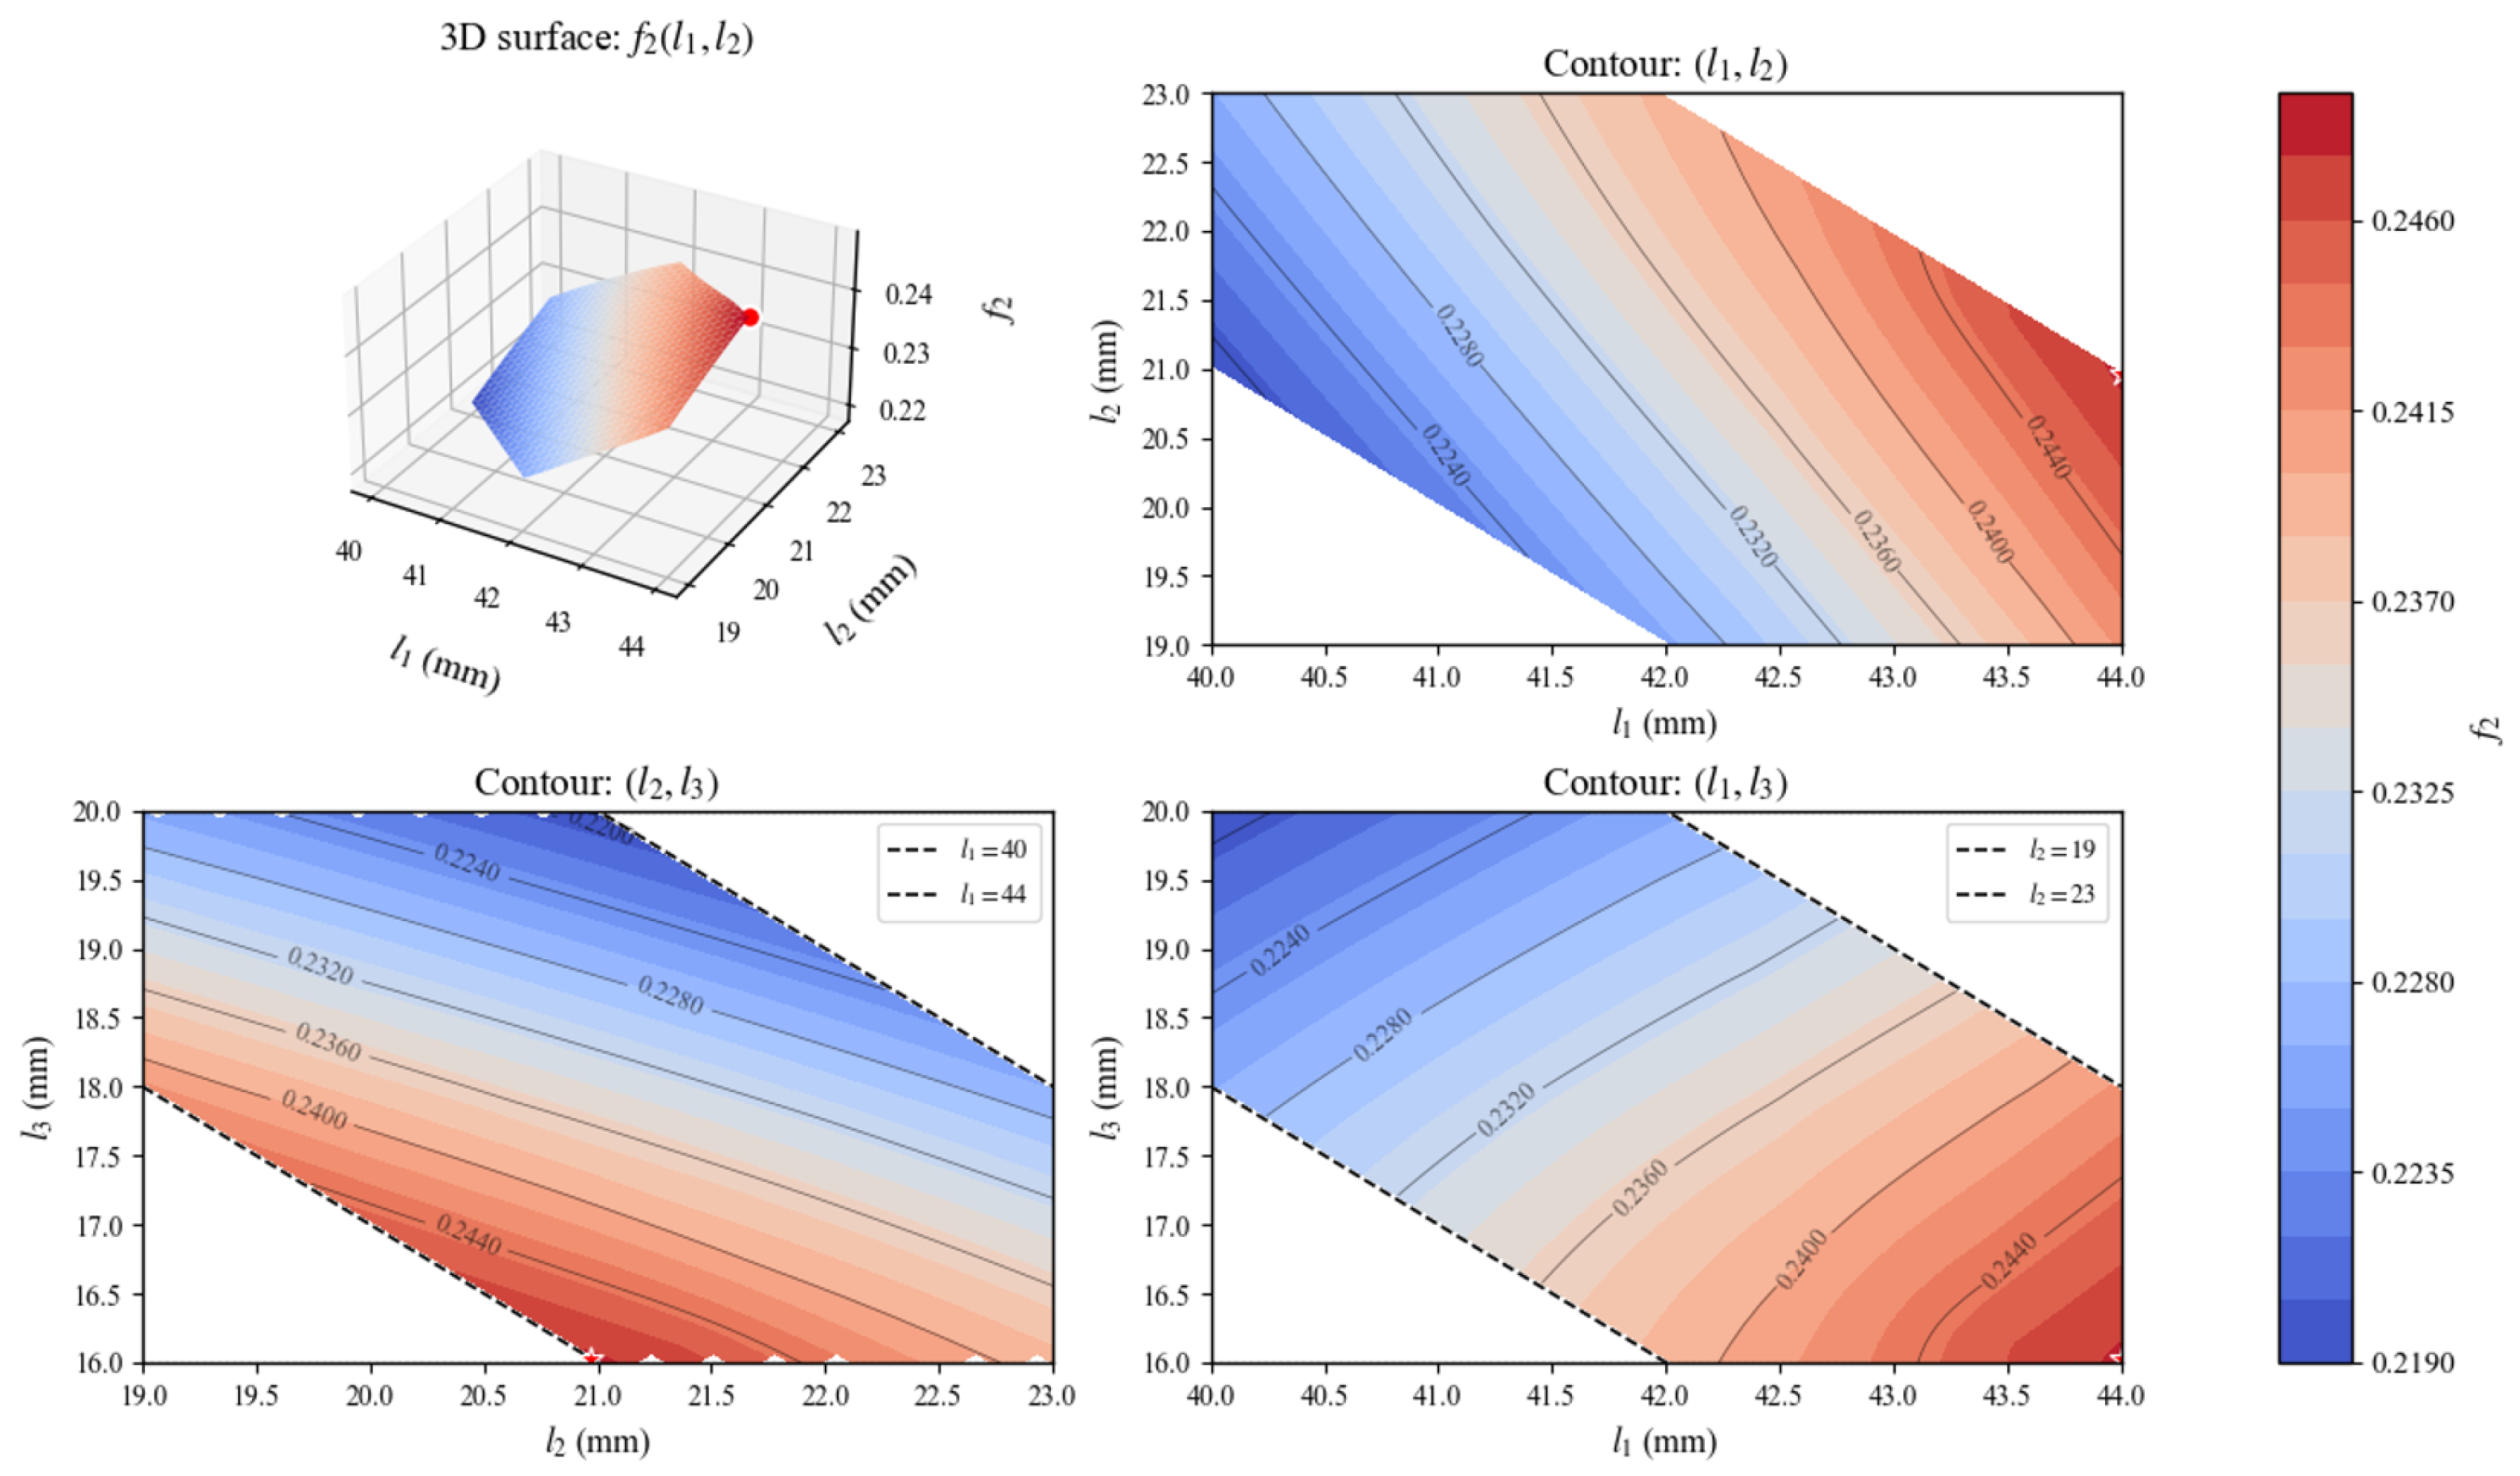
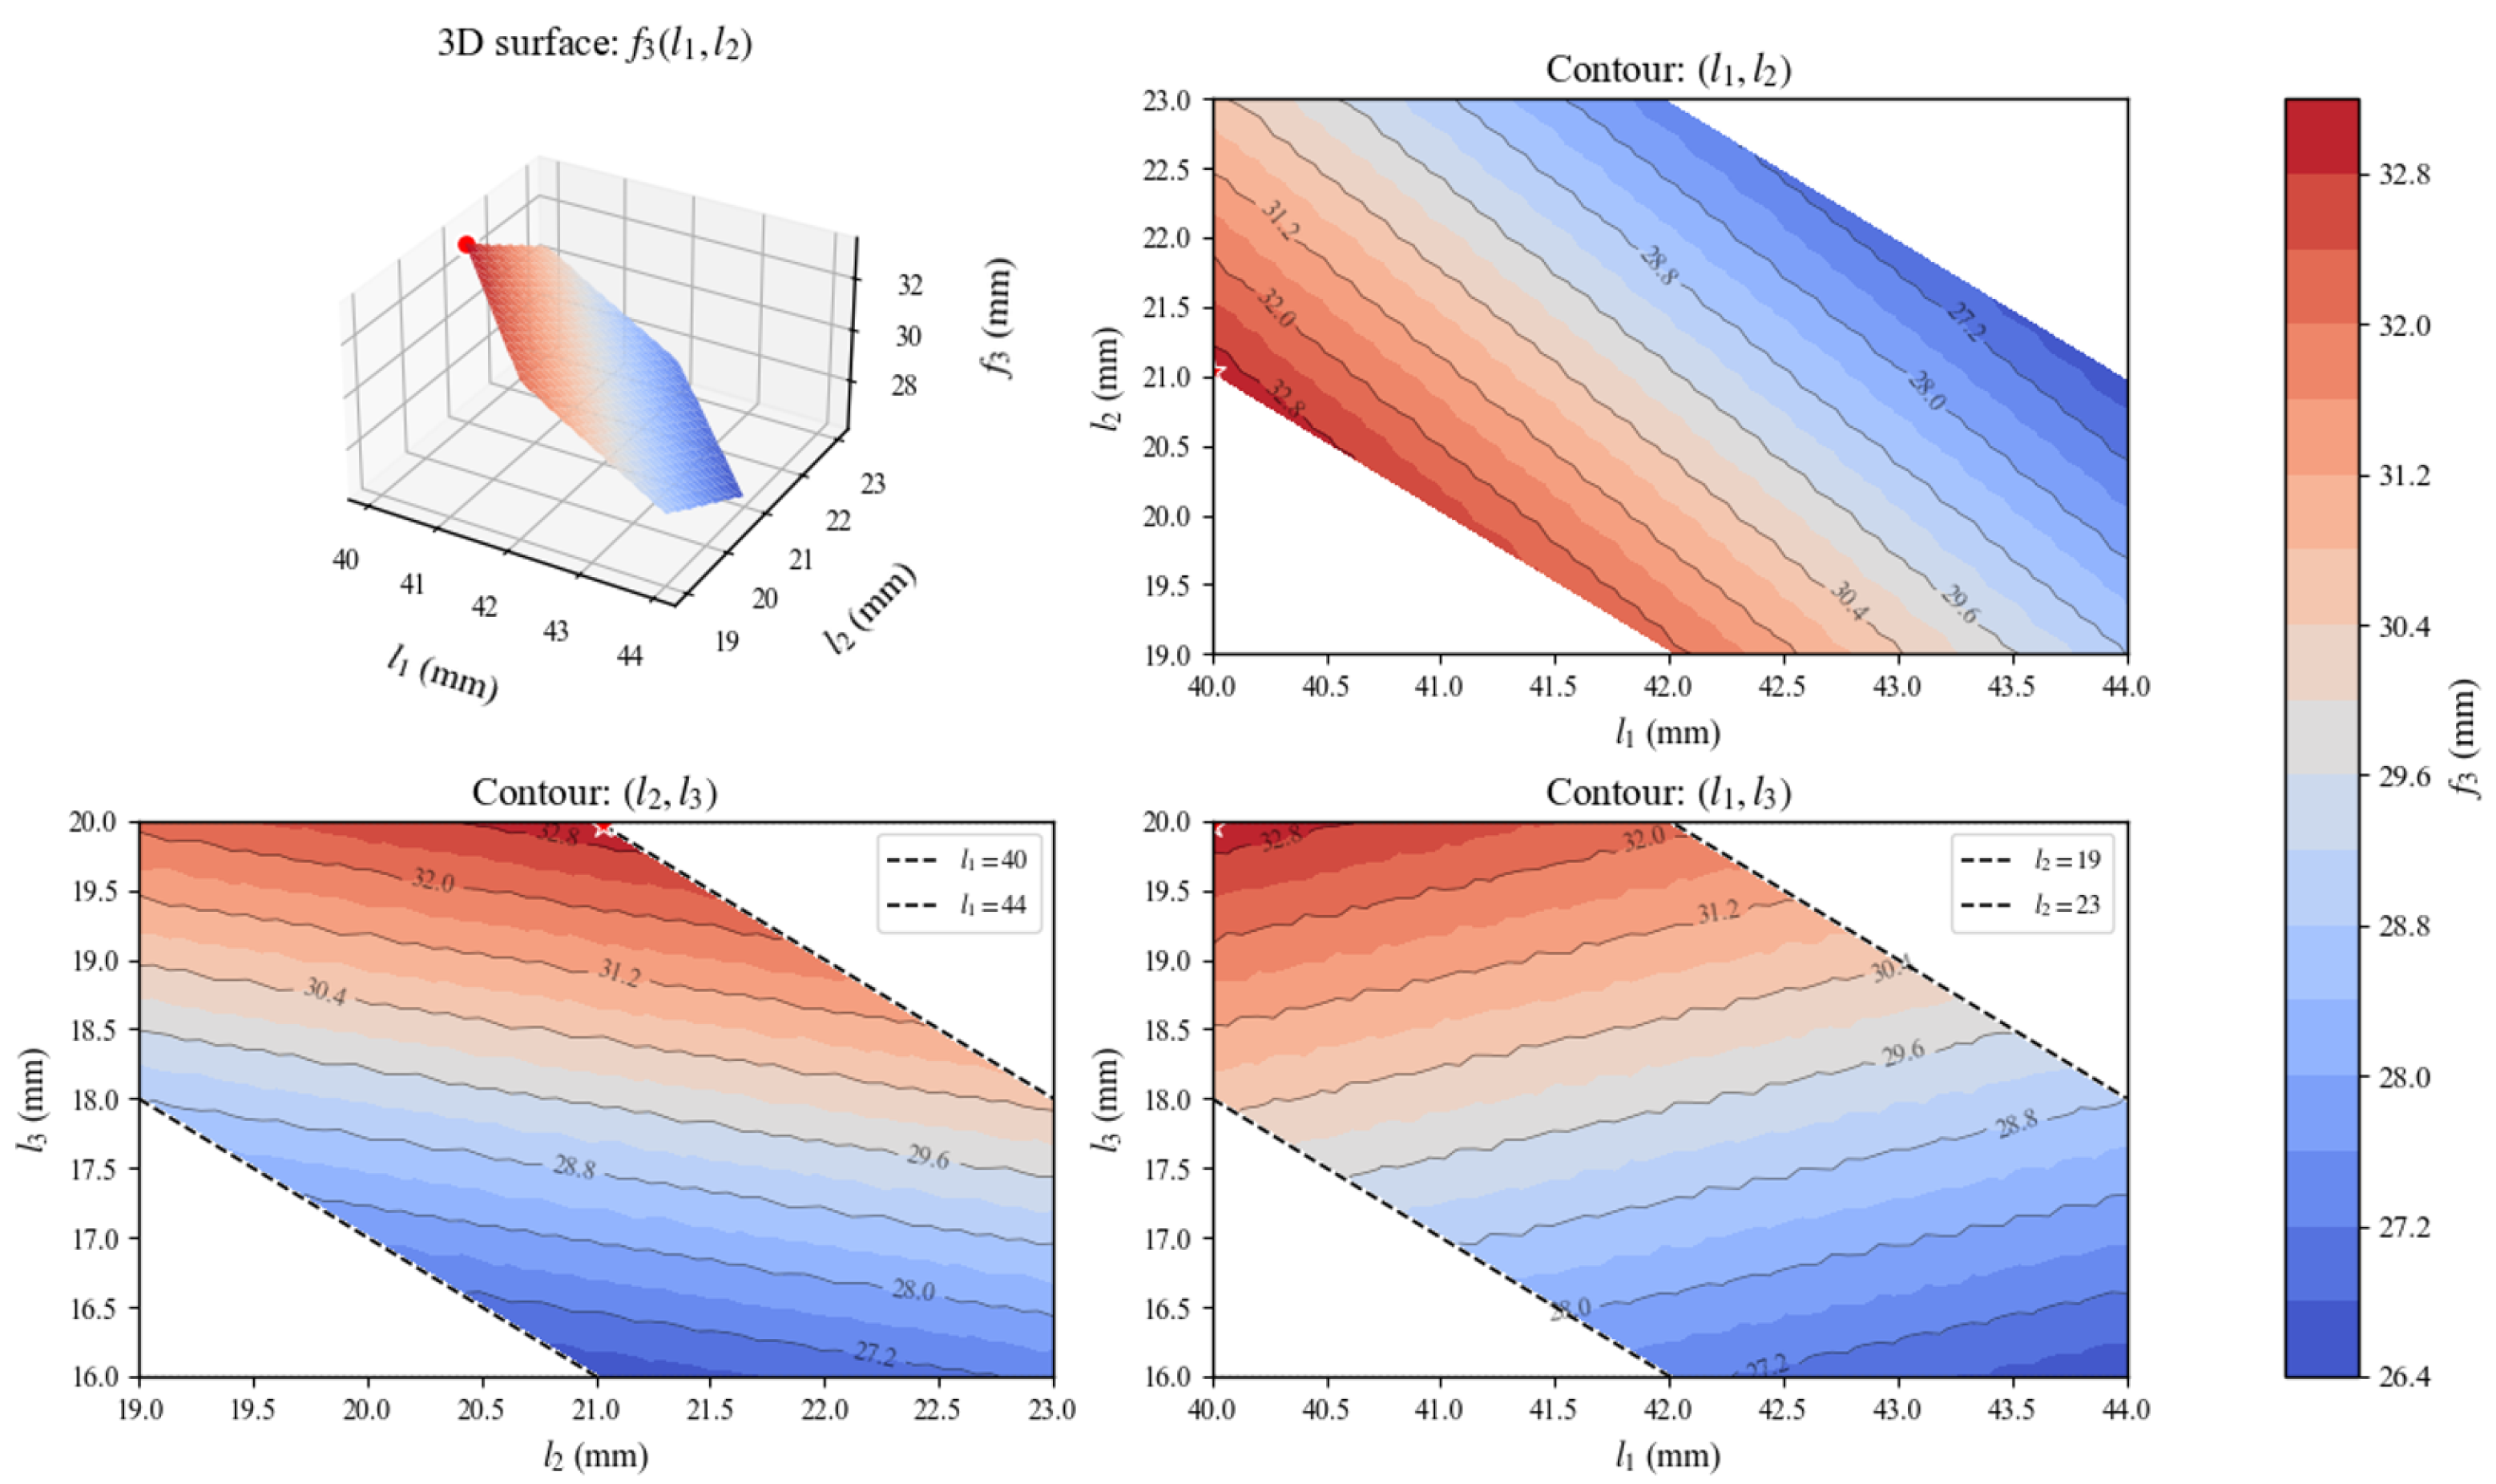
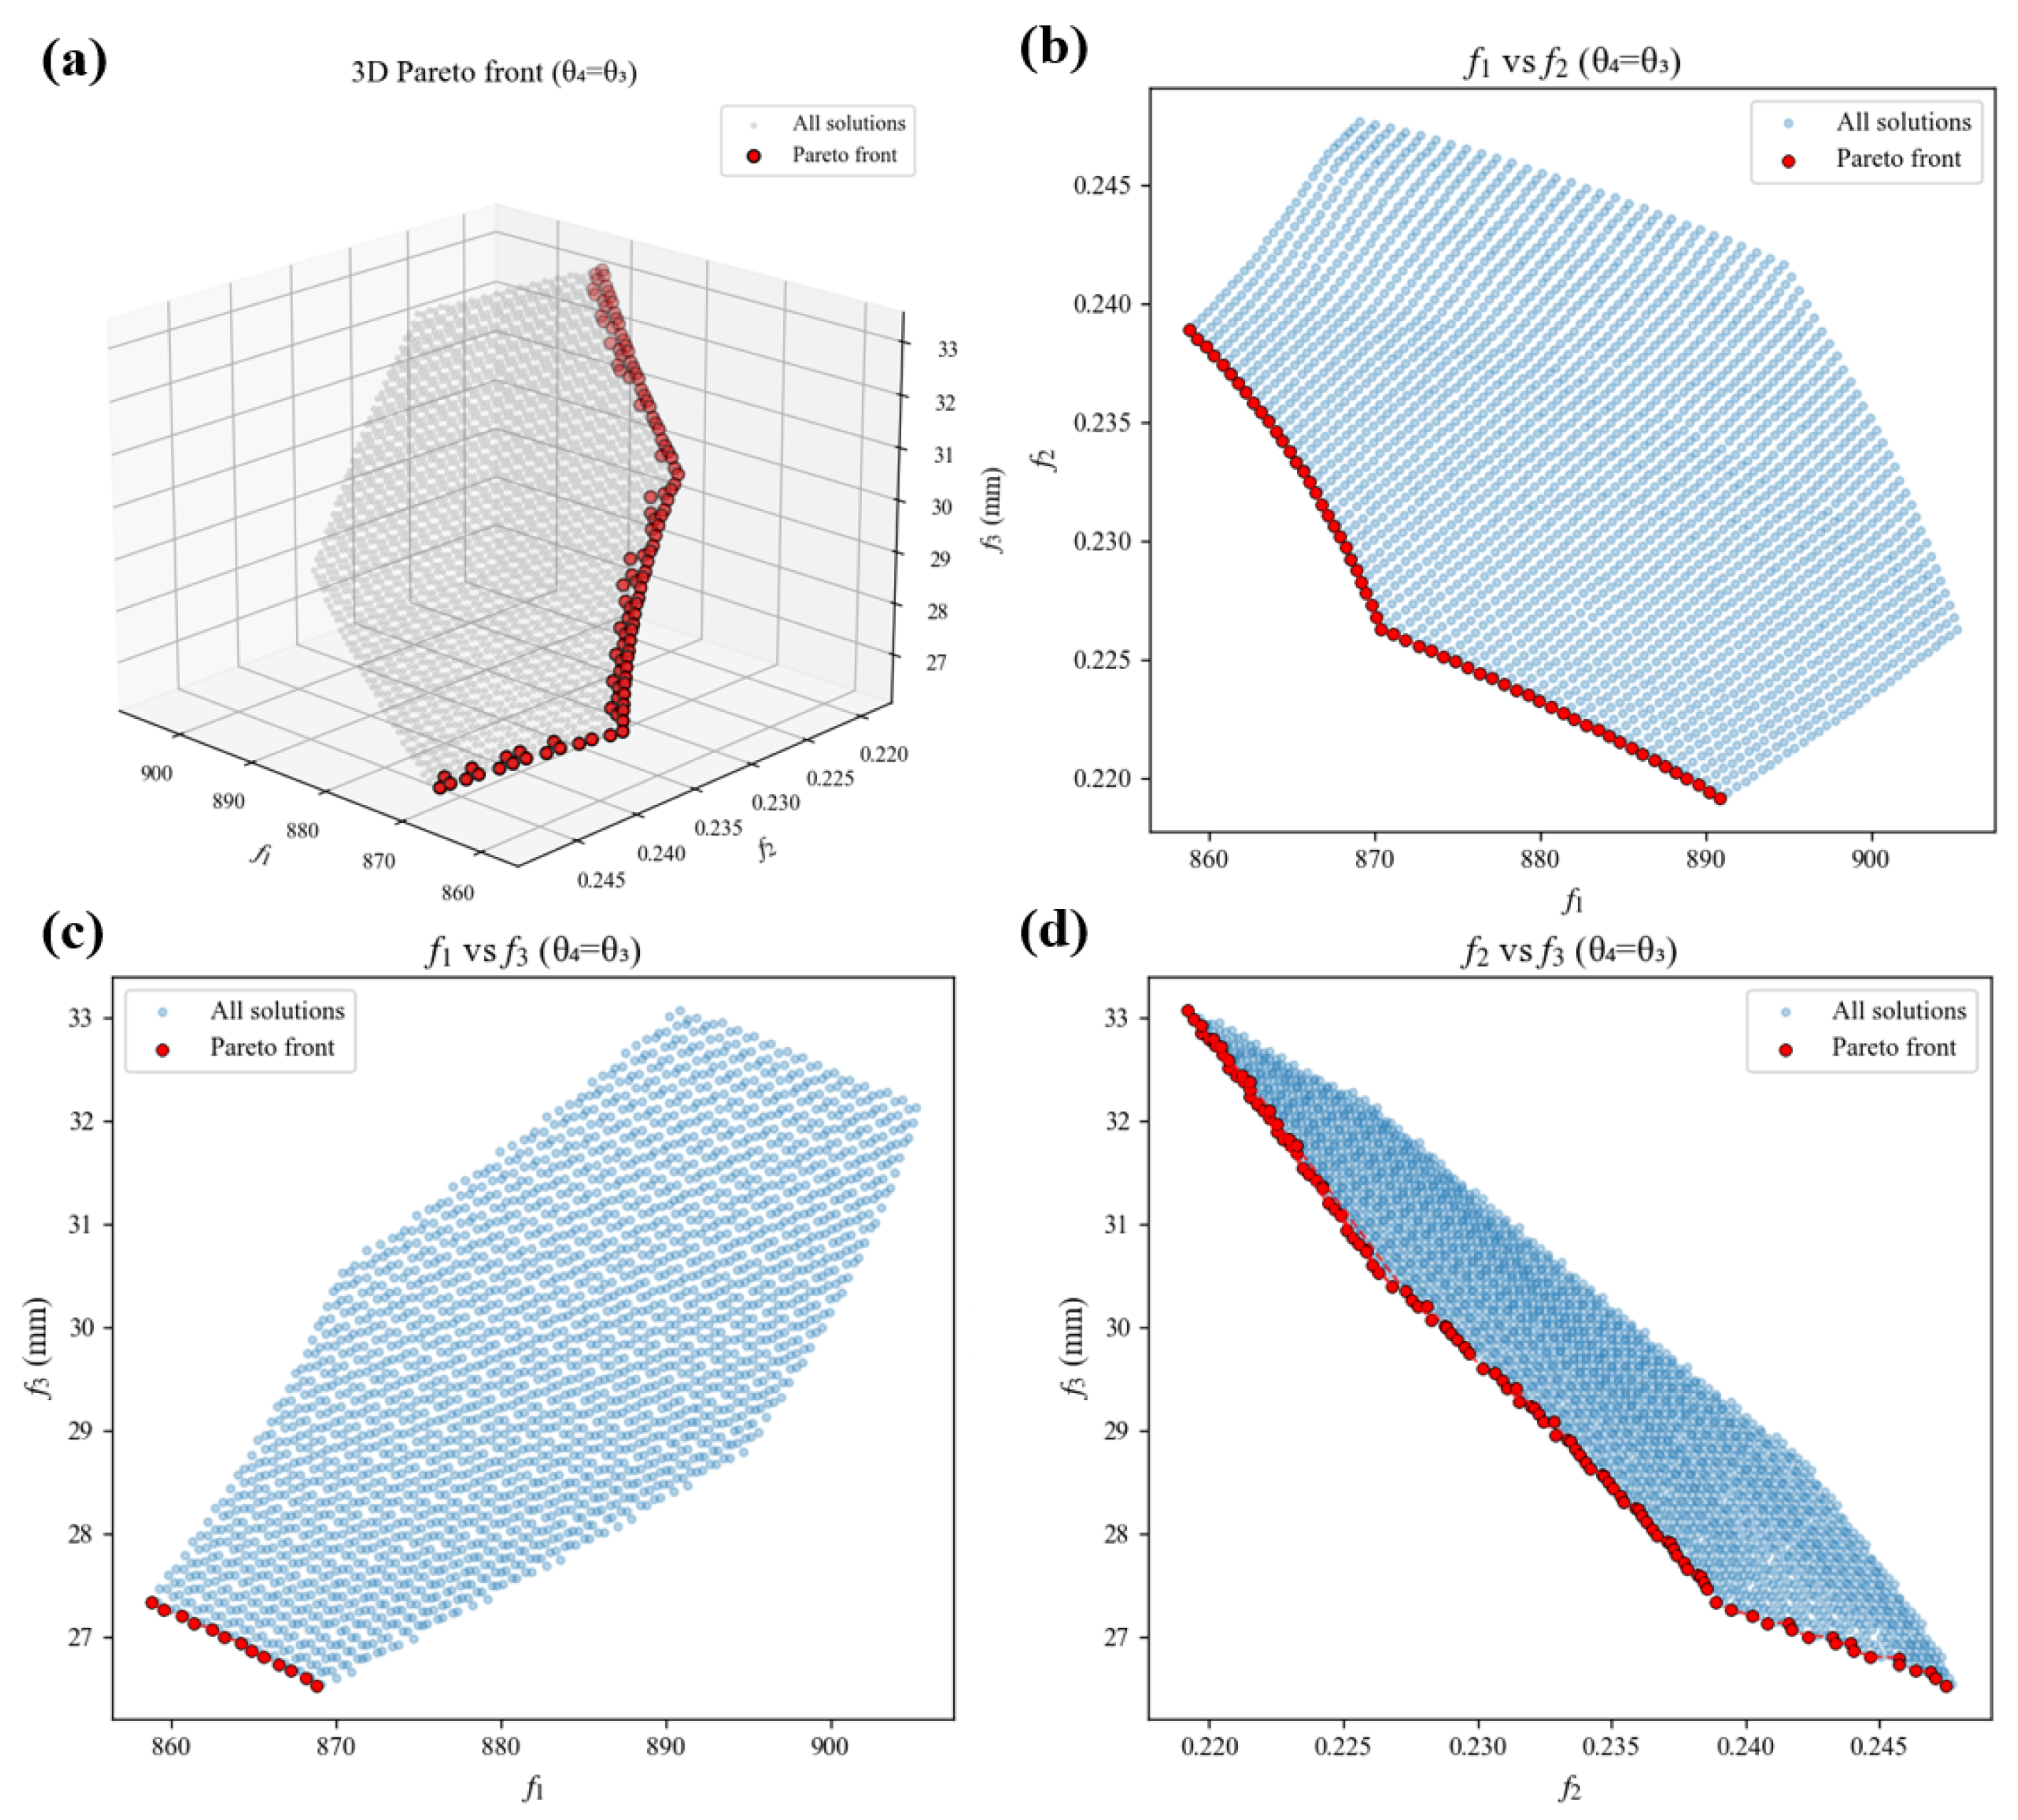
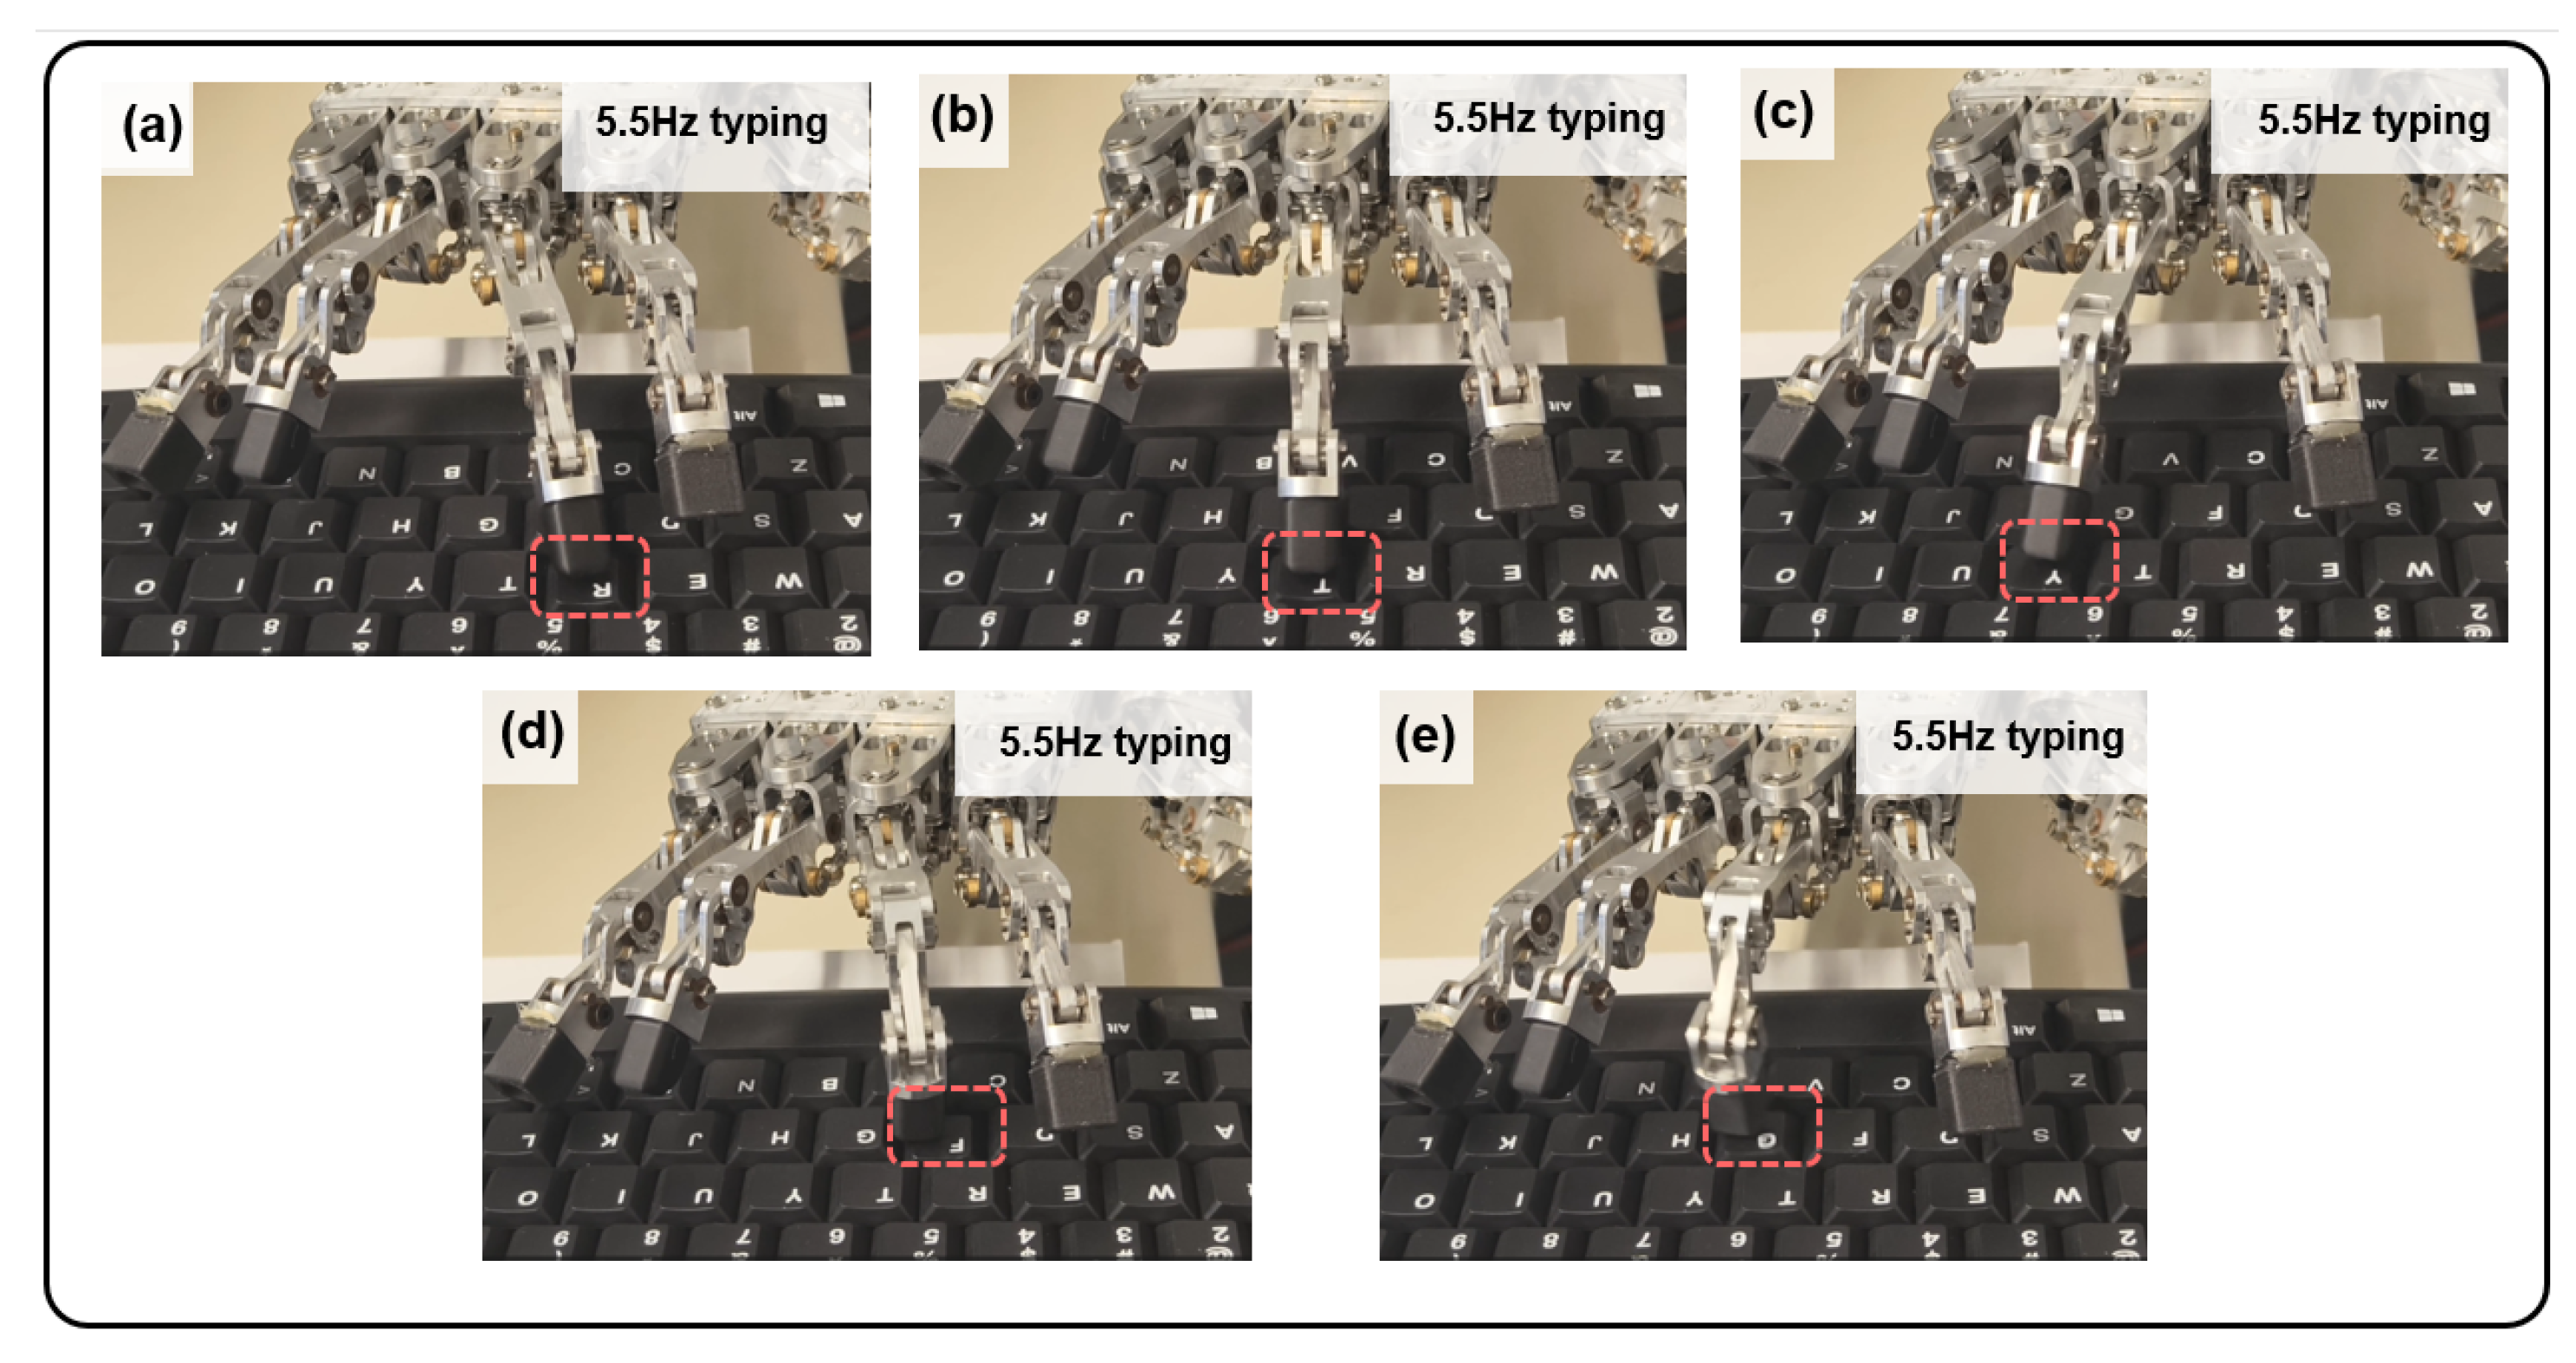
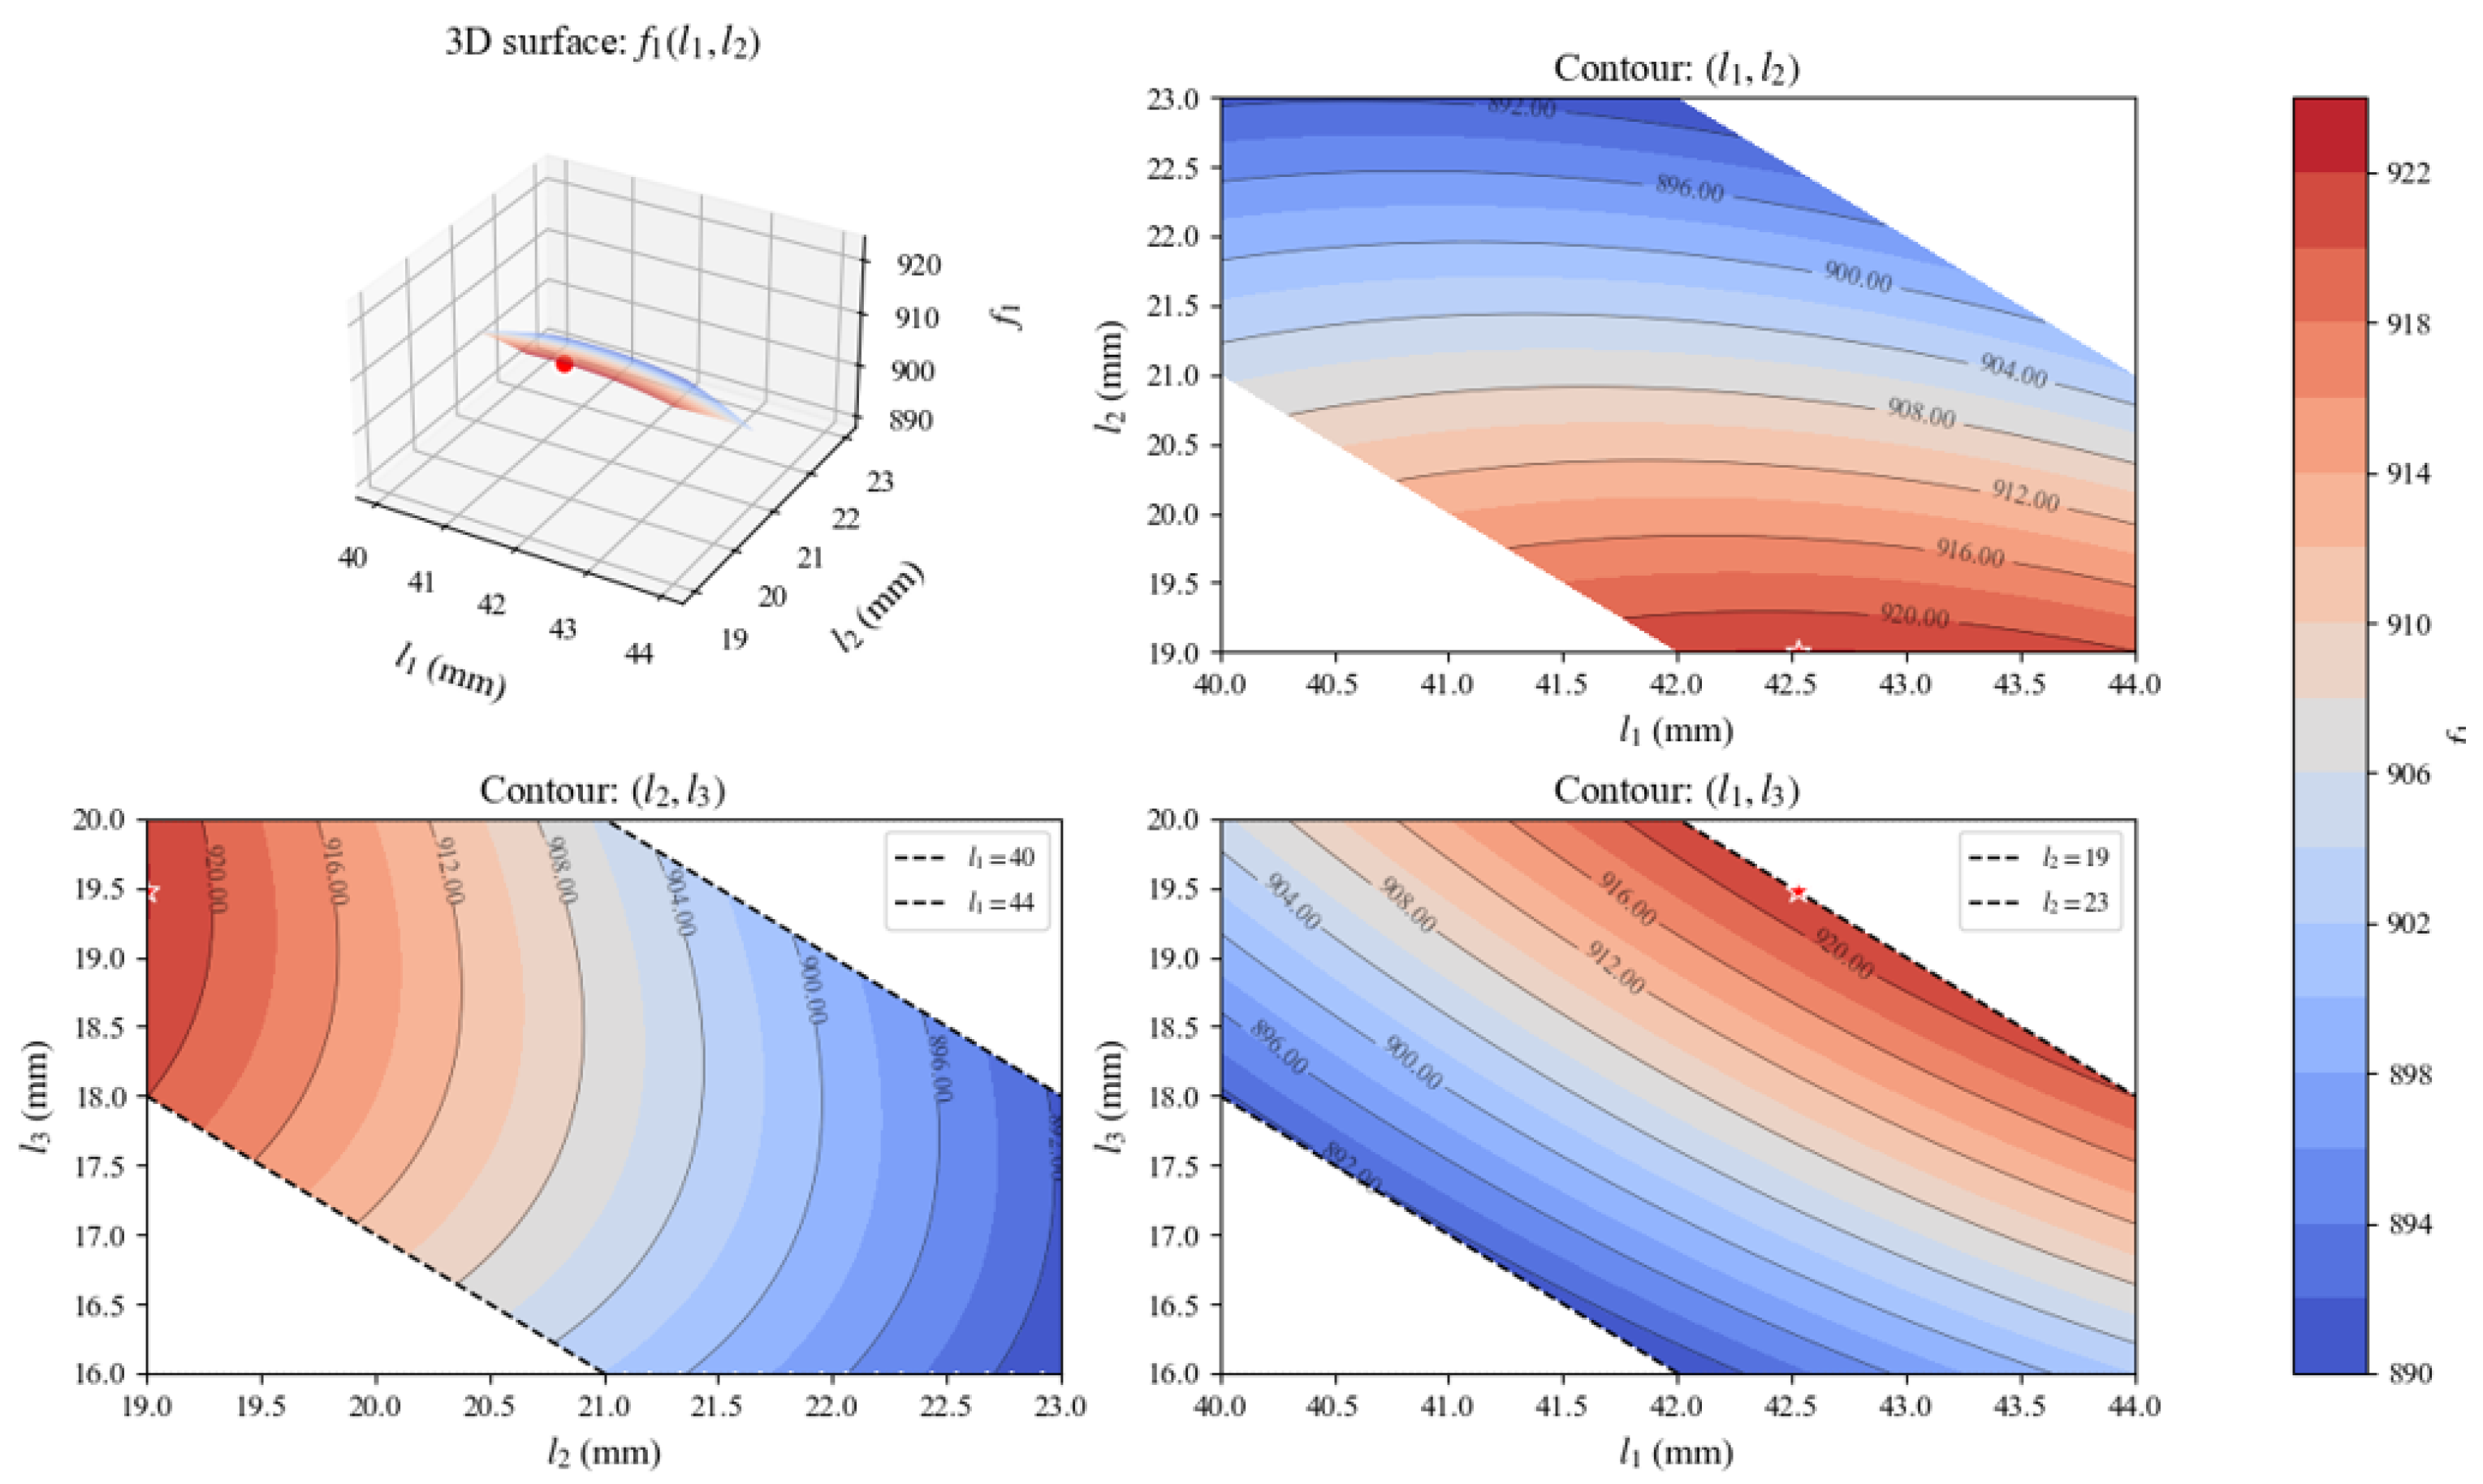
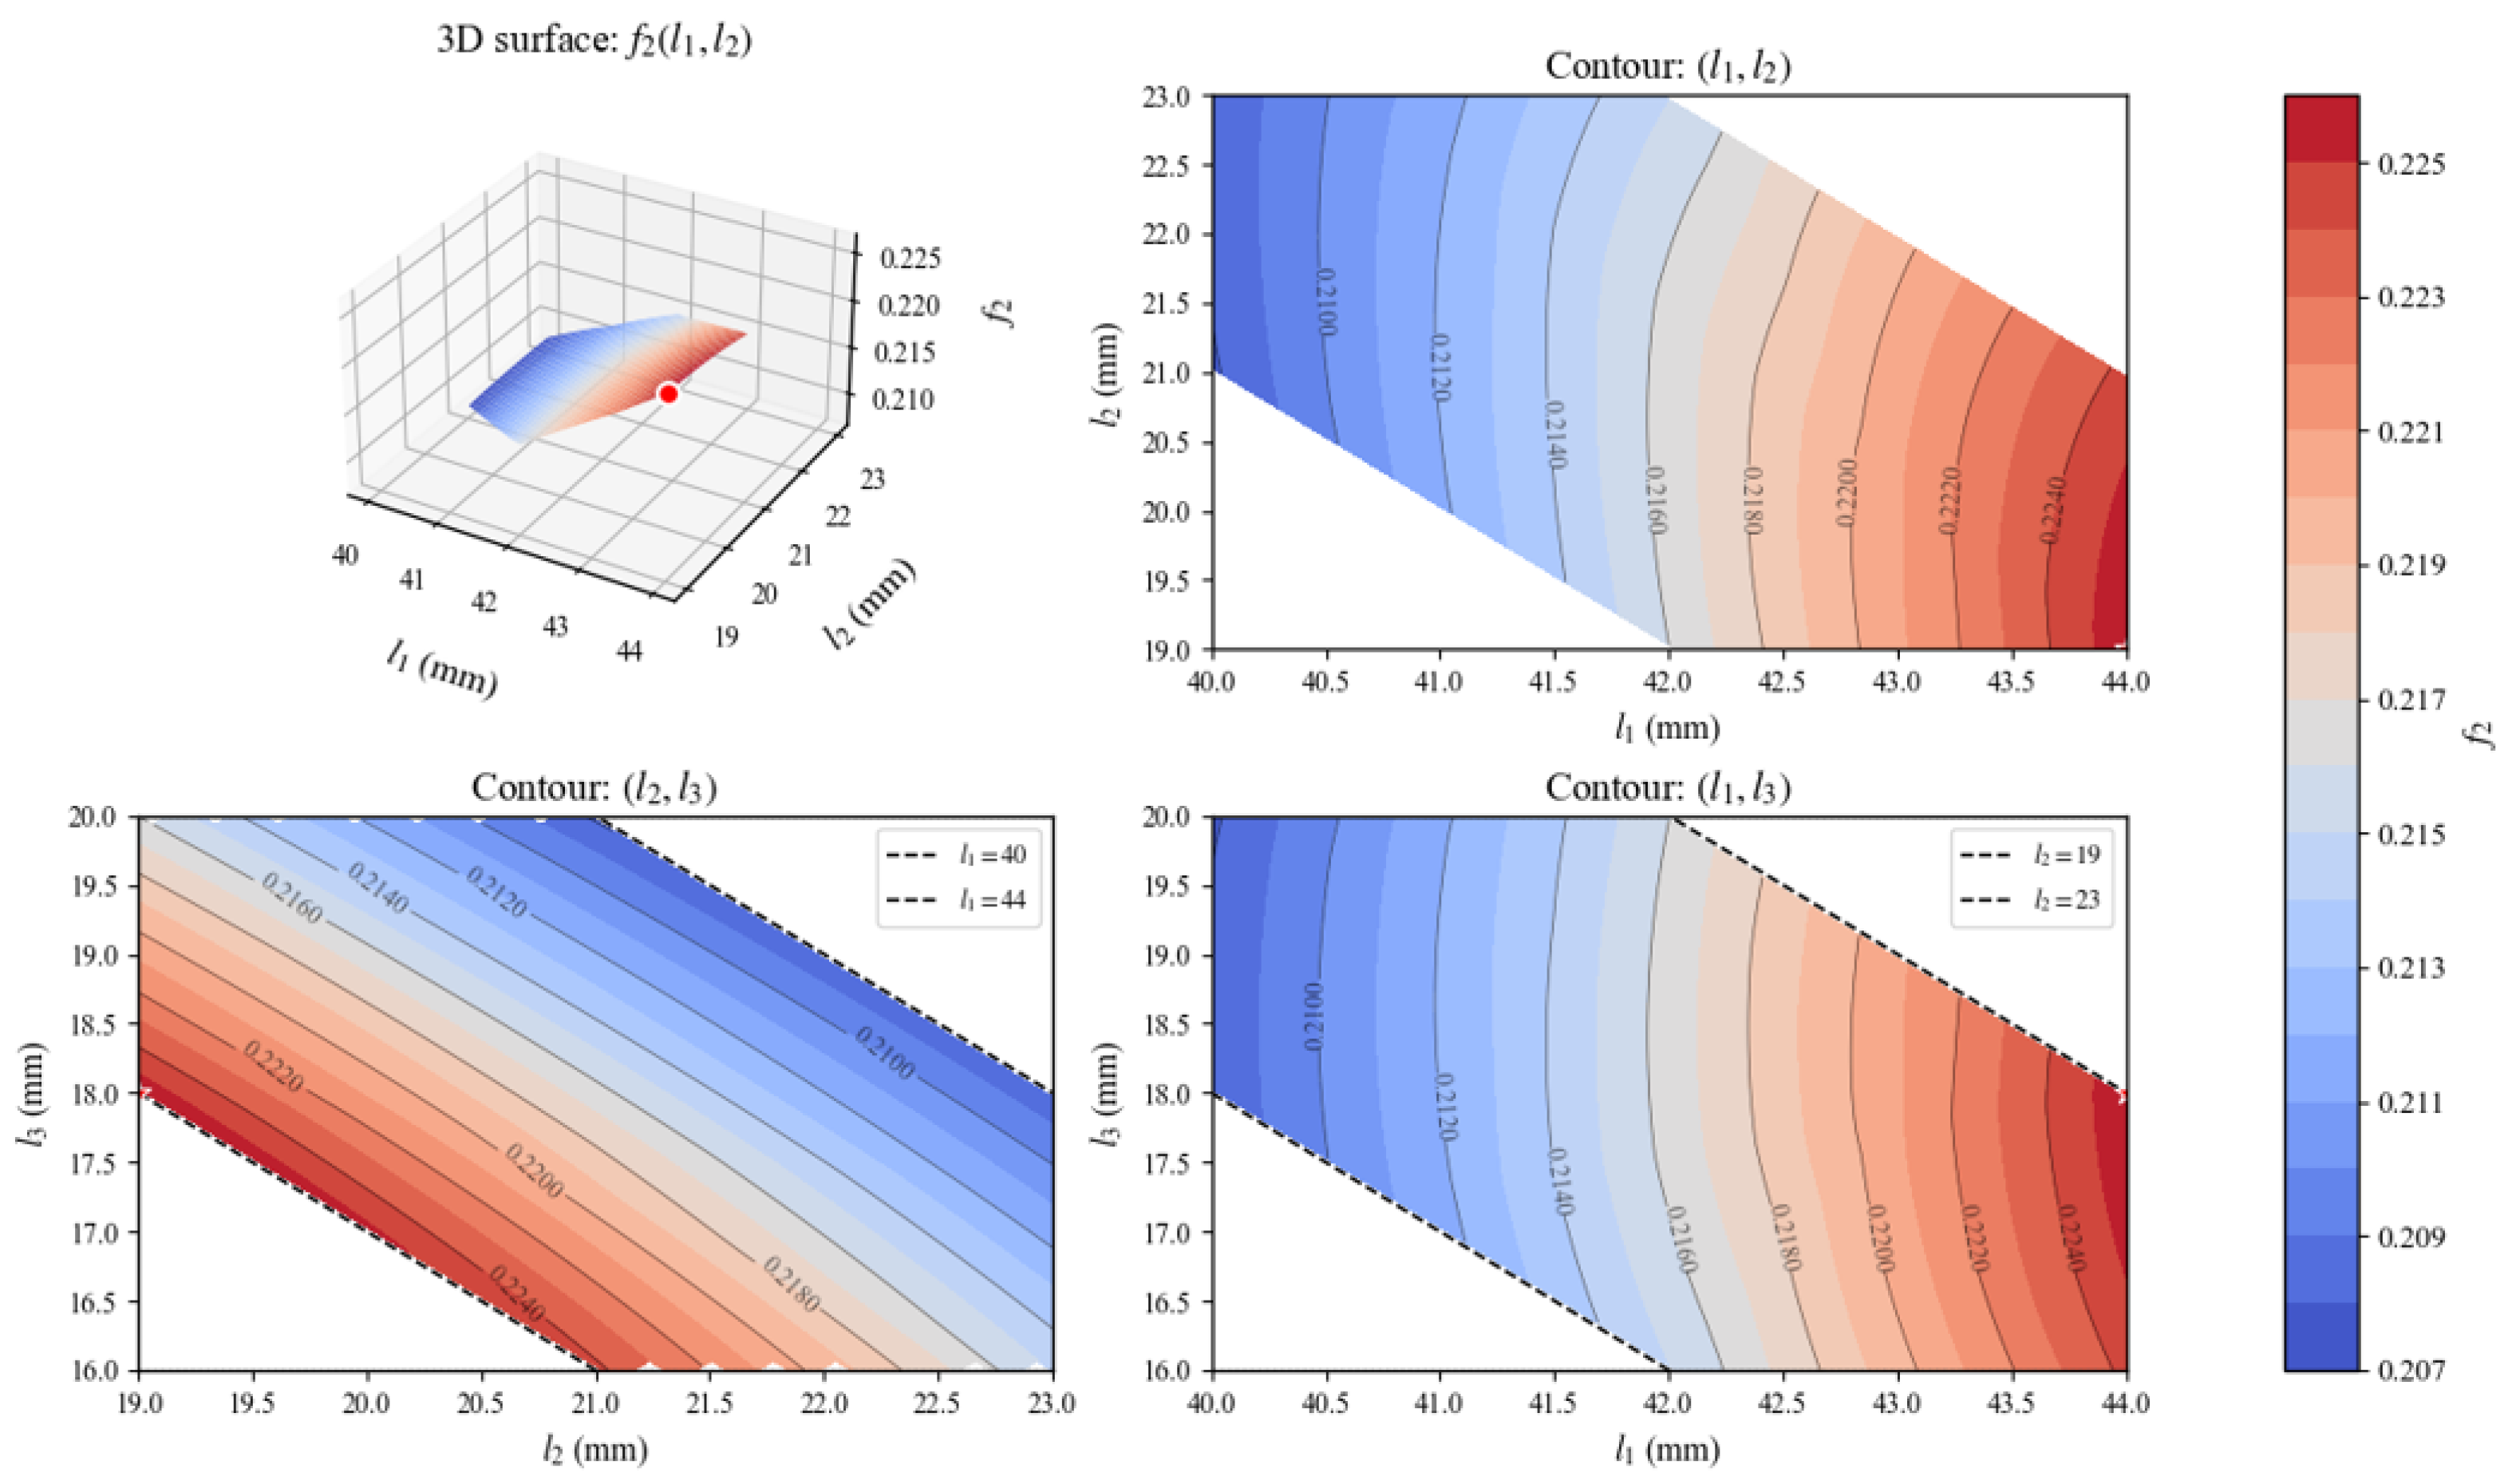
The inherent trade-off between structural compactness and functional versatility poses a fundamental challenge in biomimetic robotic hand design. This paper presents a multi-objective optimization framework for determining the optimal phalanx length allocation of a biomimetic finger under a fixed total-length constraint. Three performance criteria are formulated: grasp capability, measured by the area of a novel shared workspace (Region II) between power grasping and precision manipulation; kinematic dexterity, evaluated as the global average of the reciprocal condition number of the Jacobian matrix; and key-press range, defined as the maximum static fingertip span under perpendicularity and slope constraints. A full grid search reveals distinct optimal configurations for each objective. Pareto analysis of 117 non-dominated solutions shows that the key-press range is most sensitive to dimensional variations, with a 24.7% performance spread. A hierarchical selection strategy that prioritizes the key-press range while balancing the other two objectives yields a recommended compromise design. Experimental validation of the key-press reachability for the recommended compromise design achieves a 98.8% keystroke success rate over 1000 cross-row strikes without wrist movement. These results confirm its practical feasibility for fine manipulation tasks, while experimental characterization of the grasp capability and kinematic dexterity objectives remains as future work.
Keywords: biomimetic finger; multi-objective optimization; phalanx length; Pareto optimality; workspace analysis; kinematic dexterity; key-press range biomimetic finger; multi-objective optimization; phalanx length; Pareto optimality; workspace analysis; kinematic dexterity; key-press range