


Abstract
This paper considers the model-following preview control problem for a class of continuous-time descriptor systems with actuator failures. Firstly, the model-following problem is transformed into an optimal preview control problem by utilizing restricted equivalent transformations and the construction of augmented systems. After discussing the relationship between the stabilizability and detectability of the augmented system and the corresponding characteristics of the controlled system, the model-following preview controller of the original descriptor system is obtained by integrating on the controller of the augmented system. Finally, an application to electrical circuit system is used for assessment purposes. The simulation results demonstrate the effectiveness of the proposed controller.
MSC:
49N05
1. Introduction
A descriptor system is also known as a differential algebraic system or a singular system, etc. Compared with a normal system, its form is more extensive. It was formed and developed in the 1970s. Rosenbrock first proposed the descriptor system and studied the decoupling zero point and the restricted equivalent transformation of the descriptor system [1]. After that, the existence and uniqueness of the solutions of the descriptor system were discussed in [2]. Since then, many control scholars have begun to explore this new study field; however, there are relatively few research results on model-following control based on descriptor systems.
The model-following control method in the normal system was extended to the descriptor system, and the model-following controller designing method for a class of linear descriptor systems with disturbance was proposed in [3]. Wu et al. presented a model-following control method for a discrete-time nonlinear descriptor system and showed the constraint conditions to ensure that the output tracking error was asymptotically convergent to a zero vector [4]. Zhao and Okubo discussed a model-following controller designing method for a continuous-time nonlinear descriptor system [5]. The H∞ model-following controller was proposed for a class of linear parameter-varying descriptor systems [6]. The robust model reference controller was designed by Tian and Duan for uncertain second-order descriptor systems, and sufficient conditions were given to guarantee the complete parameterization of the robust controller [7]. The robust model-following control problem for high-order descriptor systems with norm-bounded parameter uncertainties was investigated in [8].
Preview control is a control technique that utilizes future information to improve system transient response and enhance tracking performance. At present, the basic theory of preview control has been basically constructed [9,10,11,12,13], which has made progress in the research of the multirate system [14], the descriptor system [15,16,17], the stochastic system [18,19], and the multi-agent system [20,21] and is widely applied to practical projects such as aircraft, wind turbines, vehicle stability control and so on [22,23,24,25].
Model-following control is an important theoretical method in fault-tolerant control. The major idea is to establish a reference model and to realize the tracking of the reference model by designing the controller of the controlled system. Motivated by [26], this article researches the model-following problem for a class of continuous-time descriptor systems with actuator failures by introducing a normal control system with a known input vector as the reference model. The main contributions are summarized as follows:
- (1)
- Unlike traditional preview control, the output of the reference model is desired to be a signal, and the input of the reference model is a previewable signal.
- (2)
- The fault-tolerant preview control theory previously proposed for normal systems is extended to a descriptor system, and this theory is successfully applied to a real electrical circuit system.
The structure of this article is as follows: The system model and related assumptions are presented in Section 2. The restricted equivalent transformation of the descriptor system is enunciated in Section 3. Section 4 presents the main results, which contain the establishment of an augmented system and a global optimal preview controller. Conditions for the existence of the controller are drawn in Section 5. In Section 6, the effectiveness of the theoretical results was verified through a simulation. Conclusions are provided in Section 7.
2. Model and Related Assumptions
Consider the following linear continuous-time descriptor system with actuator failures
where , , , and are state vectors, input vectors, output vectors, and known fault vectors, respectively. , , , , and are known constant matrices, and .
The fault-free reference model is described by
where , , and are reference state vectors, reference output vectors, and known reference input vectors, respectively. , , and are known constant matrices [26].
System (2) describes the ideal dynamic performance of the closed-loop system, and is equivalent to the desired signal in the traditional preview control technology, but the reference signal is generated by the reference input vector (this is a previewable signal) in the given reference model instead of given directly. The failure of the controlled system will lead to an increase in the error between and . Therefore, how to design the controller to make the controlled system still asymptotically track the output vector of the reference model under the condition of failure is a key issue in this paper.
We define the tracking error vector as
The goal of this article is to design a model-following controller with preview compensation for descriptor fault system (1) to eliminate the effect of the fault signal on the system output and to make the output of closed-loop system (1) track the output of reference model (2) without static error, that is, the output error is asymptotically stable to the zero vector:
According to the research objectives of this article, the quadratic performance index function is given as follows:
where and are positive definite matrices. Introducing into the performance index function can enable the closed-loop system to include an integrator to help eliminate static errors [11].
The following assumptions are made regarding systems (1) and (2).
Assumption 1.
Suppose system (1) is impulse-free, namely [27]
A necessary condition is that system (1) is regular, but from [27], it is known that the impulse-free descriptor system must be regular, so the system that satisfies Assumption 1 is regular.
Assumption 2.
is stabilizable, is detectable, and
Lemma 1.
The equivalent condition for to be stabilizable is , and the equivalent condition for to be detectable is , where is any complex number that satisfies [27].
Assumption 3.
is stable, namely, the eigenvalues of the have a negative real part.
Assumption 4.
The reference input signal is piecewise continuous differentiable and satisfies
where is a constant vector. Moreover, () is previewable at each instant of time ; is the preview length of .
Assumption 5.
The fault signal is piecewise continuous differentiable and satisfies
where is a constant vector. Moreover, () is previewable at each instant of time ; is the preview length of .
Remark 1.
Assumptions 4 and 5 are the basic assumptions for previewable signals in preview control theory [28].
3. Restricted Equivalent Transformation
In order to simplify the descriptor system and make use of the conclusion of preview control, we transform system (1) into second restricted equivalent forms by a nonsingular linear transformation. According to , there always exist nonsingular matrices and , such that .
Making a nonsingular linear transformation
substituting into the first equation of system (1), we obtain
Taking left transformation matrix over both sides of (5), we obtain
Partitioning the matrices , , , and , denote
Let , where and . System (1) can be transformed into
The above transformation is usually called a restricted equivalent transformation, and system (6) is the second restricted equivalent transformation form of system (1).
It is noted that the restricted equivalent transformation does not change the regularity, stabilizability, detectability, and impulsiveness of the system [27]. Without losing generality, we can study system (1) through system (6).
Remark 2.
By [27], we can see that the following two propositions are equivalent:
- (1)
- The descriptor system is impulse-free.
- (2)
- Matrix in the second restricted equivalent transformation form of the descriptor system is reversible.
4. Augmented System and Controller Design
By assuming Assumption 1, descriptor system (1) is impulse-free, so the in the second restricted equivalent transformation is reversible. System (6) is composed of a normal system and an algebraic equation. By using the characteristic of matrix as reversible, the algebraic equation is deformed, and we can turn system (6) into a normal control system with state vector .
According to the second form of system (6), we obtain
Substituting (7) in the first and third forms of (6), system (6) becomes a normal system
and an Equation (7), where
, , , , and , .
Under the premise of maintaining dynamic characteristics, we transform descriptor system (1) with actuator failures into normal system (8) and algebraic equation (7). Therefore, we only need to consider the output tracking problem of system (8) to reference model (2). We construct an augmented system by using the method of the preview control theory.
By taking the derivative on both sides of (3), the state equation in (8) and (2), we can obtain
Combining (9), (10), and (11) and taking as the output vector, we can yield an augmented system
where
, , , , , .
Remark 3.
as the output of the augmented system (12) is reasonable due to the output of systems (1) and (2), which are and , respectively.
When using the relevant variables in (12) to represent performance index function (4), it can be rewritten as
where .
So far, the model-tracking problem in this article has been transformed into an optimal preview problem for system (12) and performance index function (13). Similar to [11], we can obtain the following theorem.
Theorem 1.
Suppose is stabilizable and is detectable. The optimal preview input of system (12) under performance index function (13) can be represented as
where matrix is a positive semi-definite matrix satisfying the algebraic Riccati equation
and
the matrix
is stable.
System (12) has the same form as system (3.4) in [11], therefore, the derivation process is similar to that of [11]. It is omitted here.
5. Conditions for the Existence of the Controller
Theorem 1 requires to be stabilizable and to be detectable; we discuss the situations that controlled system (1) needs to satisfy in order to establish these two conditions. Please note that (2) is a given system that must satisfy Assumption 3.
Lemma 2.
Under Assumption 3, the necessary and sufficient condition for to be stabilizable is that must be stabilizable and must be of full row rank.
Proof.
Based on the PBH criterion [29], the necessary and sufficient condition for to be stabilizable is that the matrix
is of full row rank, where is any complex number that satisfies . According to Assumption 3, is invertible. Therefore,
That is to say, the equivalent condition for matrix to be row full rank is that is row full rank. There are two situations to discuss below.
- (i)
- When , it is obvious that the equivalent condition for to be row full rank is that is row full rank;
- (ii)
- When and , the equivalent condition for to be row full rank is that is row full rank.
It can be known that is also full row rank from the discussion of . Therefore, we draw the conclusion to be proven by combining these discussions. Lemma 2 is proven. □
Lemma 3.
The necessary and sufficient condition for to be stabilizable is that is stabilizable [15].
Lemma 4.
The necessary and sufficient condition for to be row full rank is that is row full rank [15].
From Lemmas 2–4, we obtain the relationship between the stabilizability of the augmented system and the original descriptor system.
Theorem 2.
Under Assumption 3, the necessary and sufficient condition for to be stabilizable is that
is stabilizable and
is of full row rank.
Lemma 5.
Under Assumption 3, the necessary and sufficient condition for to be detectable is that is detectable.
Proof.
In light of the PBH criterion, the equivalent condition for to be detectable is that matrix is column full rank, where is any complex number that satisfies . Note that
According to the structure of and the invertibility of and , we yield
Lemma 5 is proven. □
Lemma 6.
The necessary and sufficient condition for to be detectable is that is detectable [15].
From Lemmas 5 and 6, we obtain the connection between the detectability of the augmented system and the original descriptor system.
Theorem 3.
Under Assumption 3, the necessary and sufficient condition for to be detectable is that is detectable.
The most important result of this article can be obtained on the basis of Theorems 1–3.
Theorem 4.
If Assumptions 1–5 hold, and
,
are positive definite matrices, the Riccati Equation (15) has a unique symmetric positive semi-definite solution, and the optimal preview input of system (1) under the performance index function (4) can be represented as
in which
,
,
,
and
are
The expression for stable matrix is (17). The initial values , and can be arbitrarily selected.
Proof.
By integrating the two sides of (14)
on , we can obtain
Since and nonsingular transformation , we have . Order , then
and we can obtain by making in this formula, and substituting this into (20), we have
And
The conclusion is proved by substituting the above formula into (21).
Note that the control effect can be improved by selecting the initial values of , and . □
Remark 4.
In (18), shows the integrator; indicates the state feedback of (1); represents the state feedback of (2); and and express the preview compensation of the reference input signal and fault signal , respectively.
Define the controller given by Equation (18) as a model-following preview controller. It also can be called a fault-tolerant preview controller in the fault-tolerant control problem.
6. Numerical Simulation
When the controller given in (18) is introduced into the original descriptor system (1), we obtain the closed-loop system
Using the method given by [30], system (22) is discretized to obtain the iteration format
where
, , T is the sampling period.
Consider the electrical circuit system with actuator failures [31], where the inductance is , the capacitance is , and the resistance is .
where , , , , .
In this model, the components of the state vector represent the current in the circuit, the voltage of the resistance, the voltage of the inductance and the voltage of the capacitance, respectively. Input vector represents the voltage source. is the voltage of the capacitance, which can be measured in a physical sense, so it is defined as the output vector of the system. is a known fault vector
Select reference model (2) as
where the reference input is a step signal
Note that output vector of (2) is the ideal value of the voltage of the capacitor.
According to the structure of matrix in system (22), it should be taken as
After the restricted equivalent transformation is carried out, system (6) is obtained, where
The corresponding matrices of the augmented system (12) are
Obviously, this example satisfies all the conditions of Assumptions 1–5. The weight matrices of performance index function (4) are taken as , . The solution of (15) and the gain matrices in (18) are
where is symmetric positive definite.
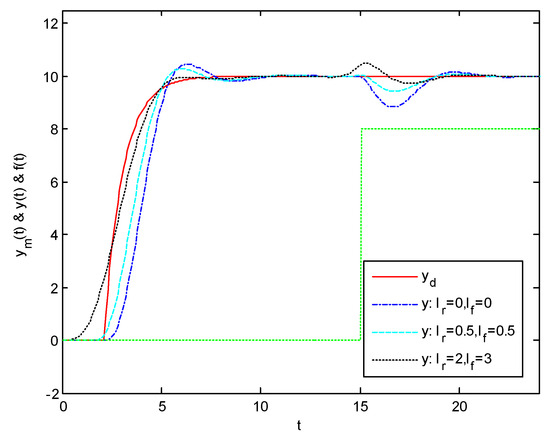
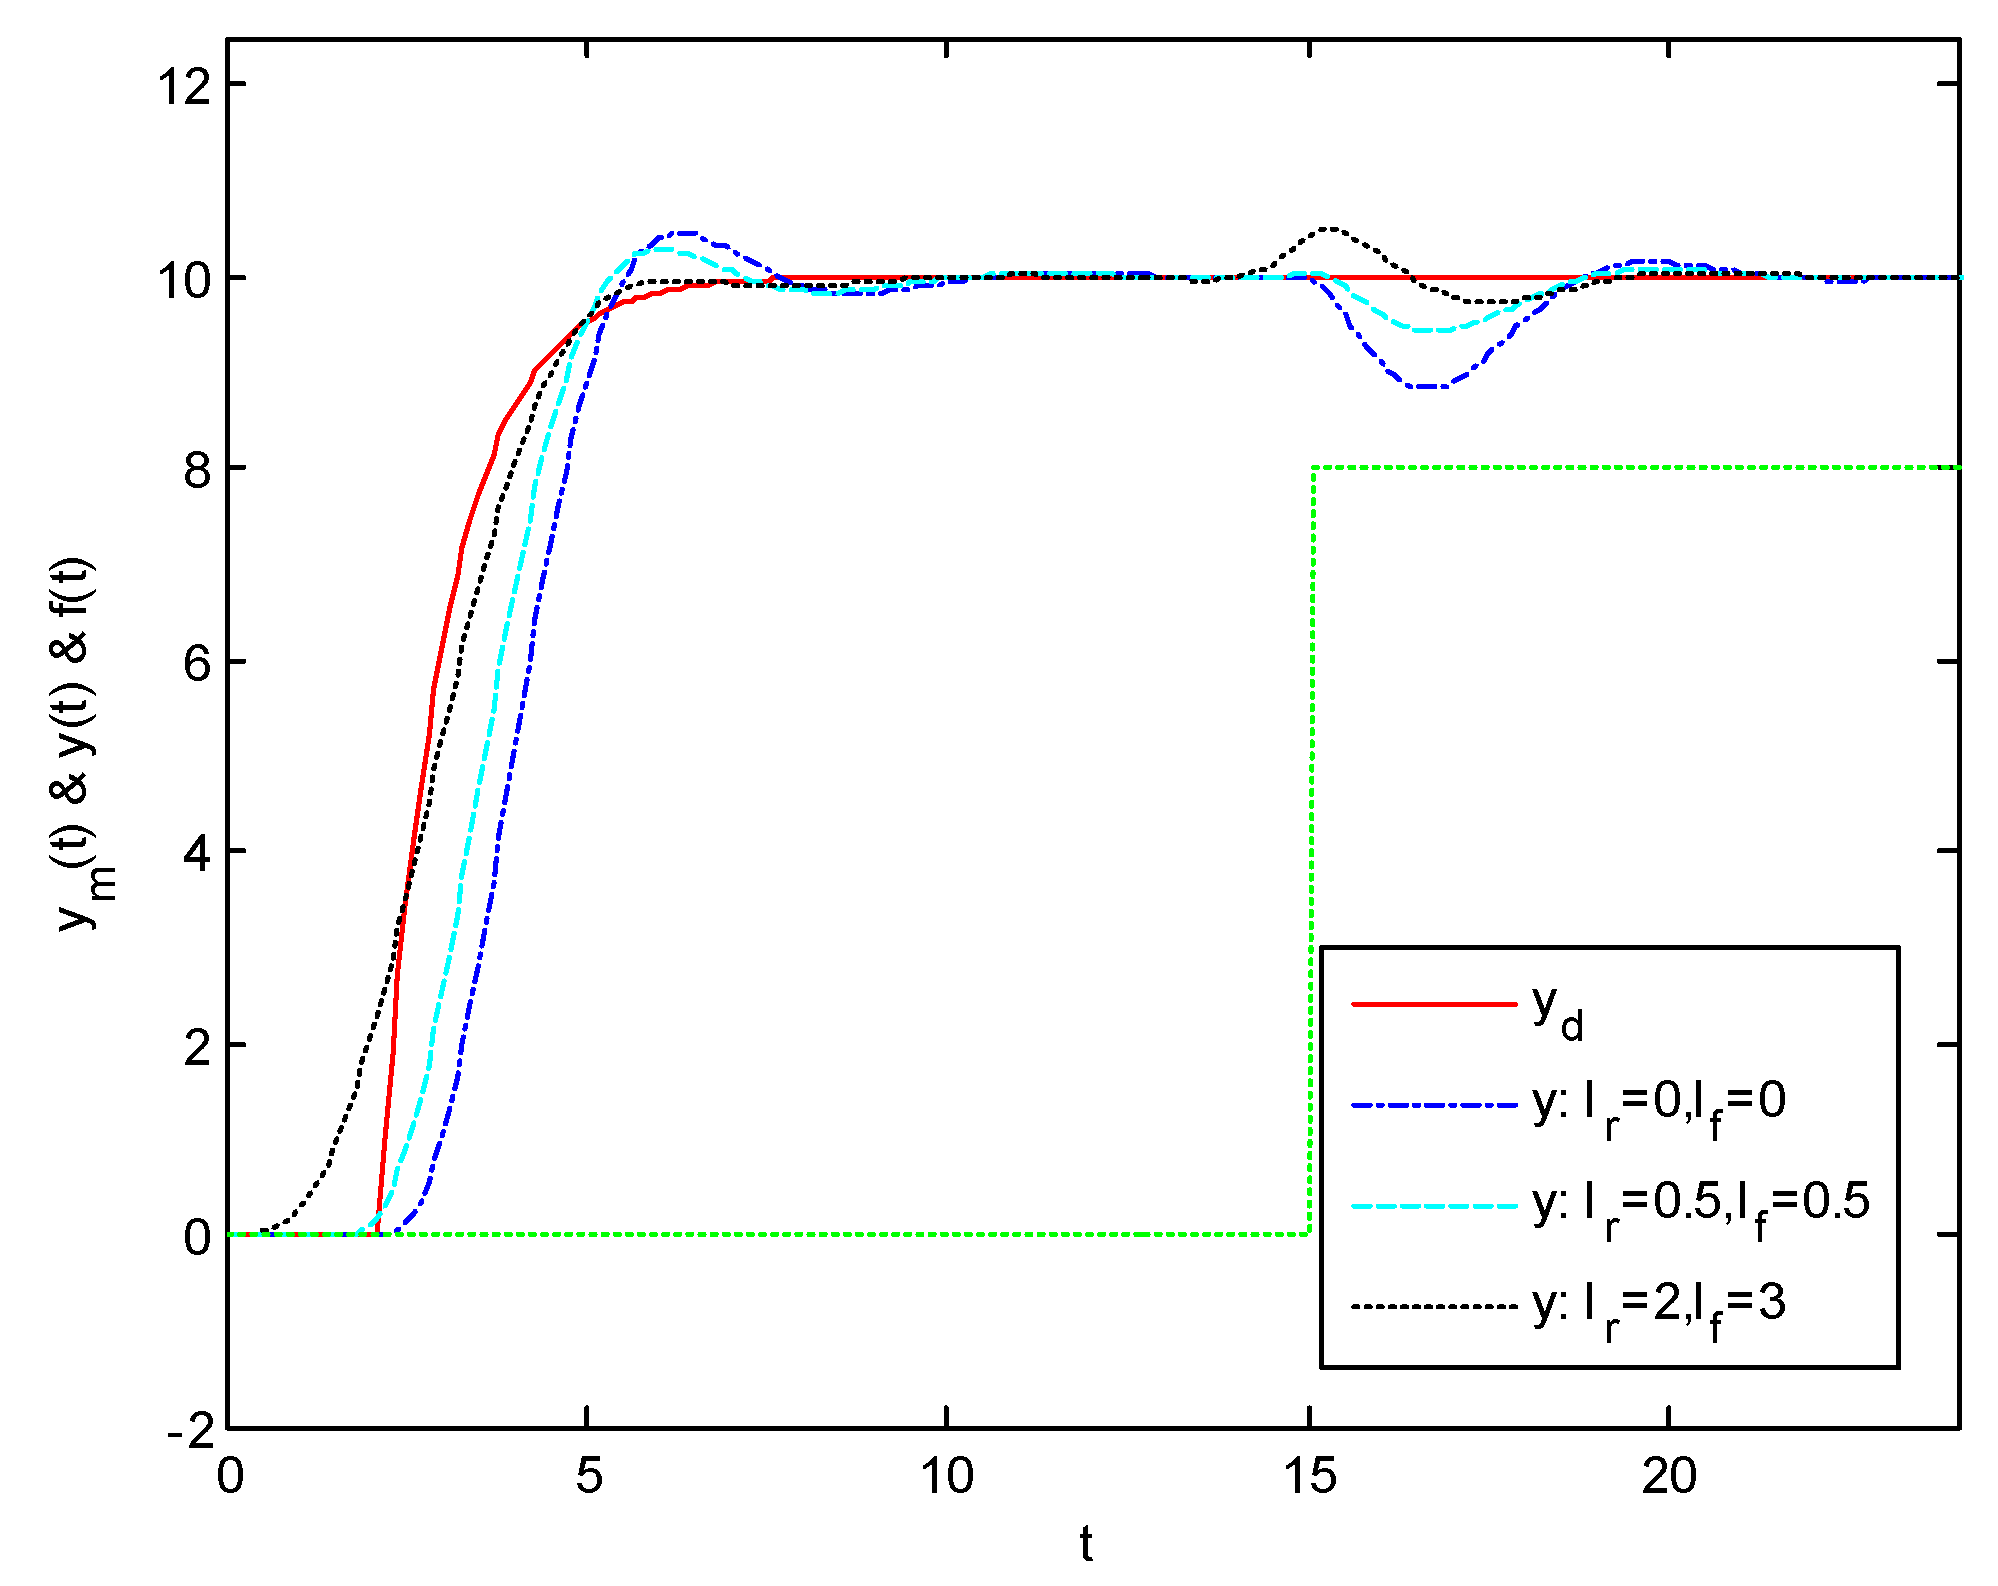
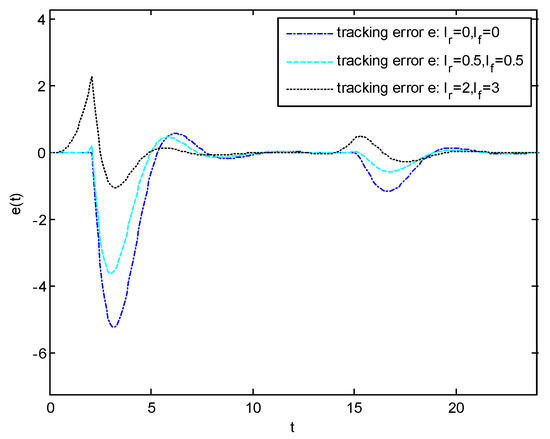
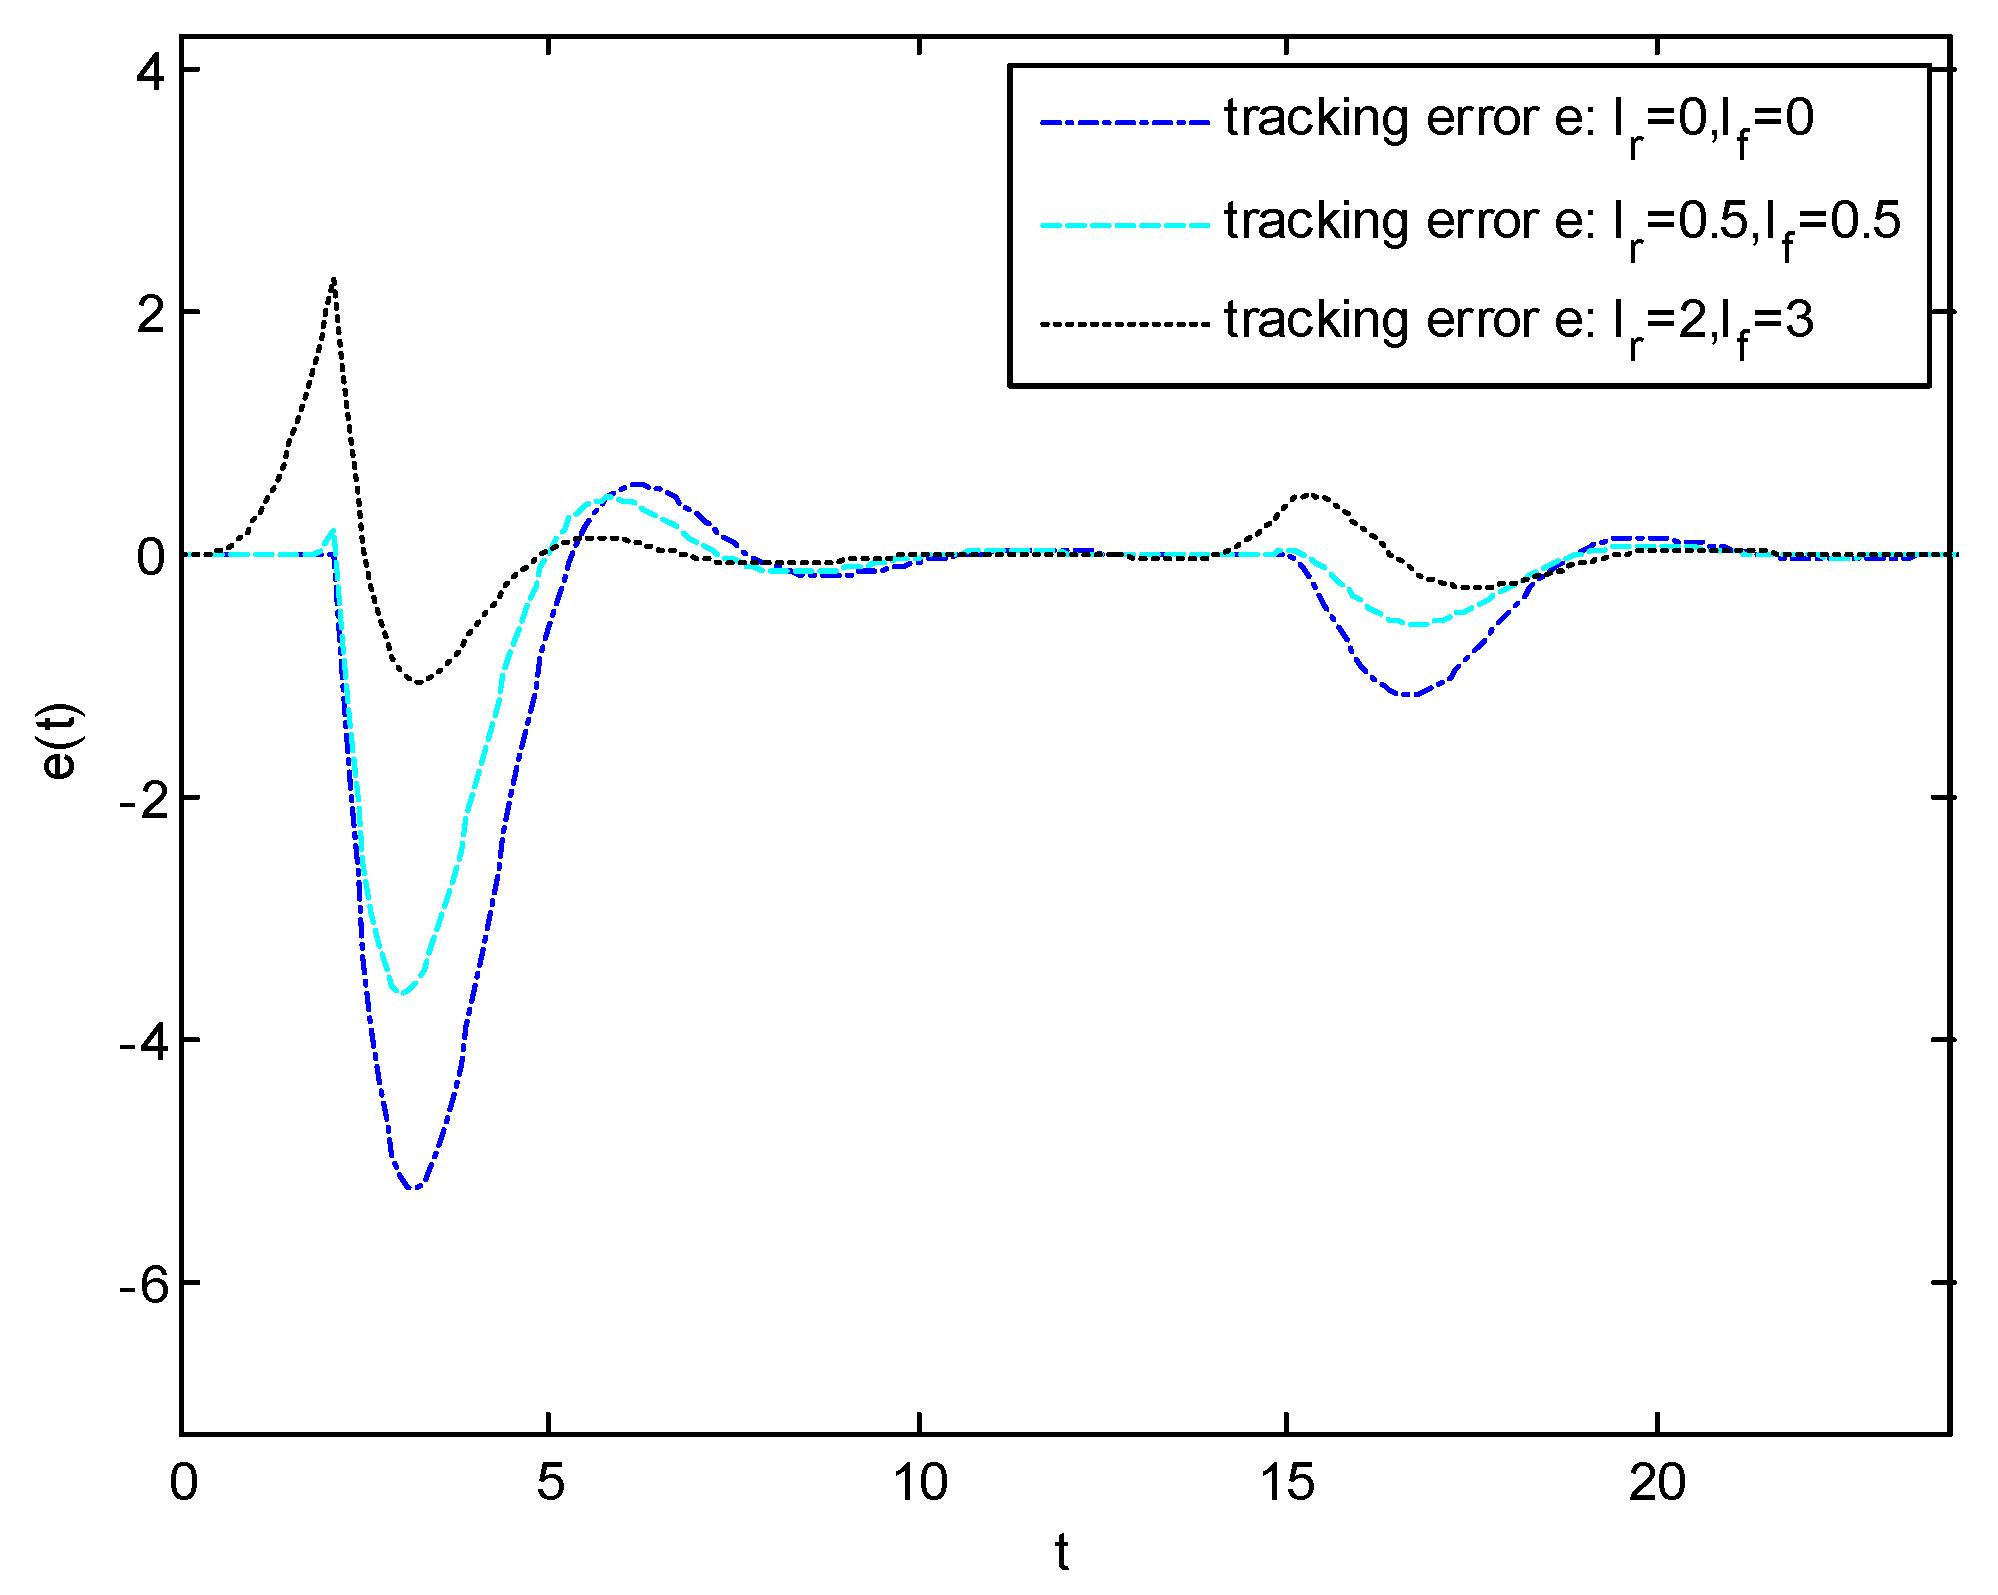
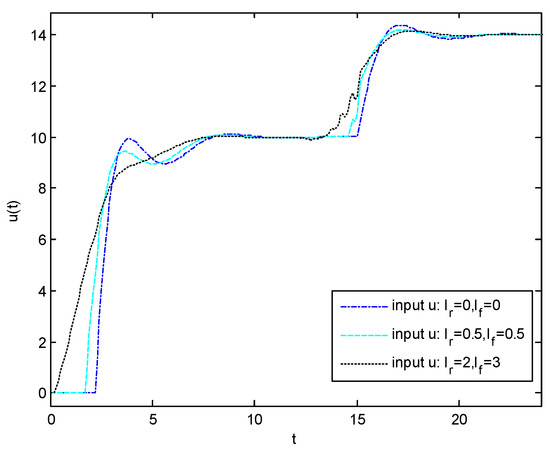
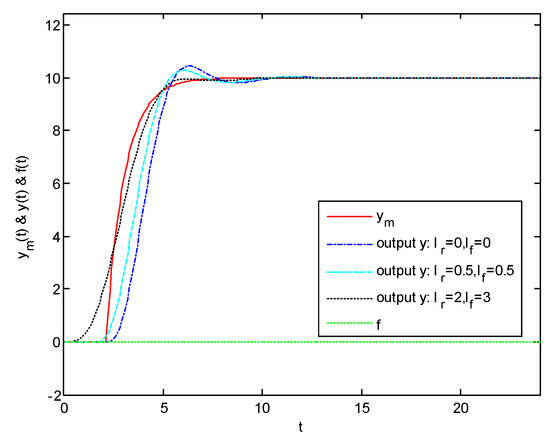
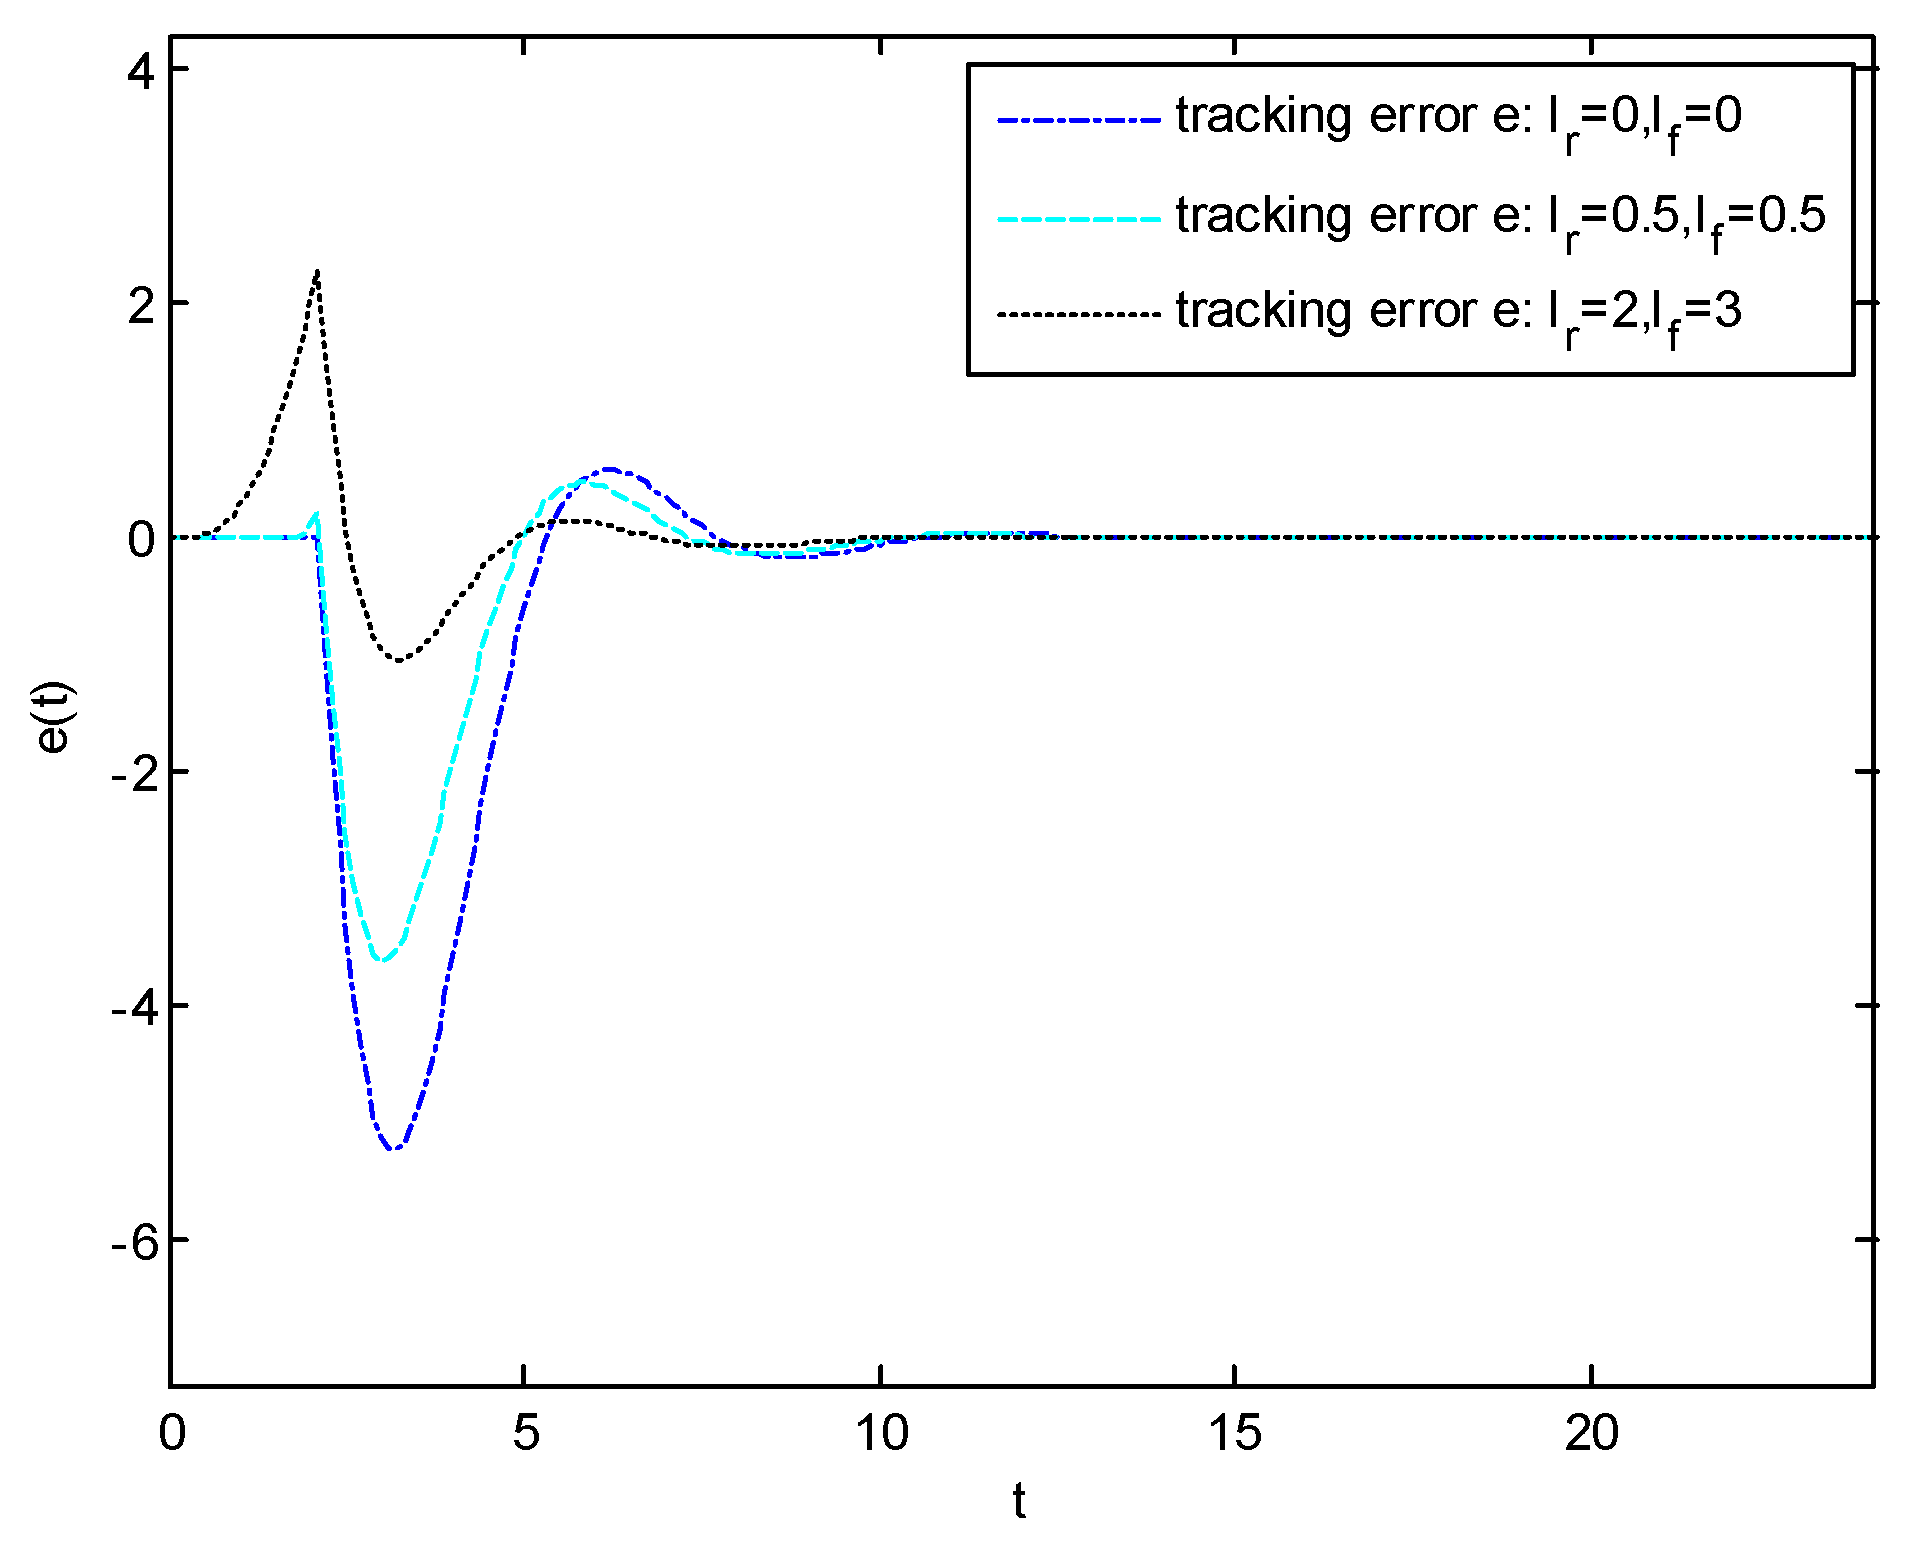
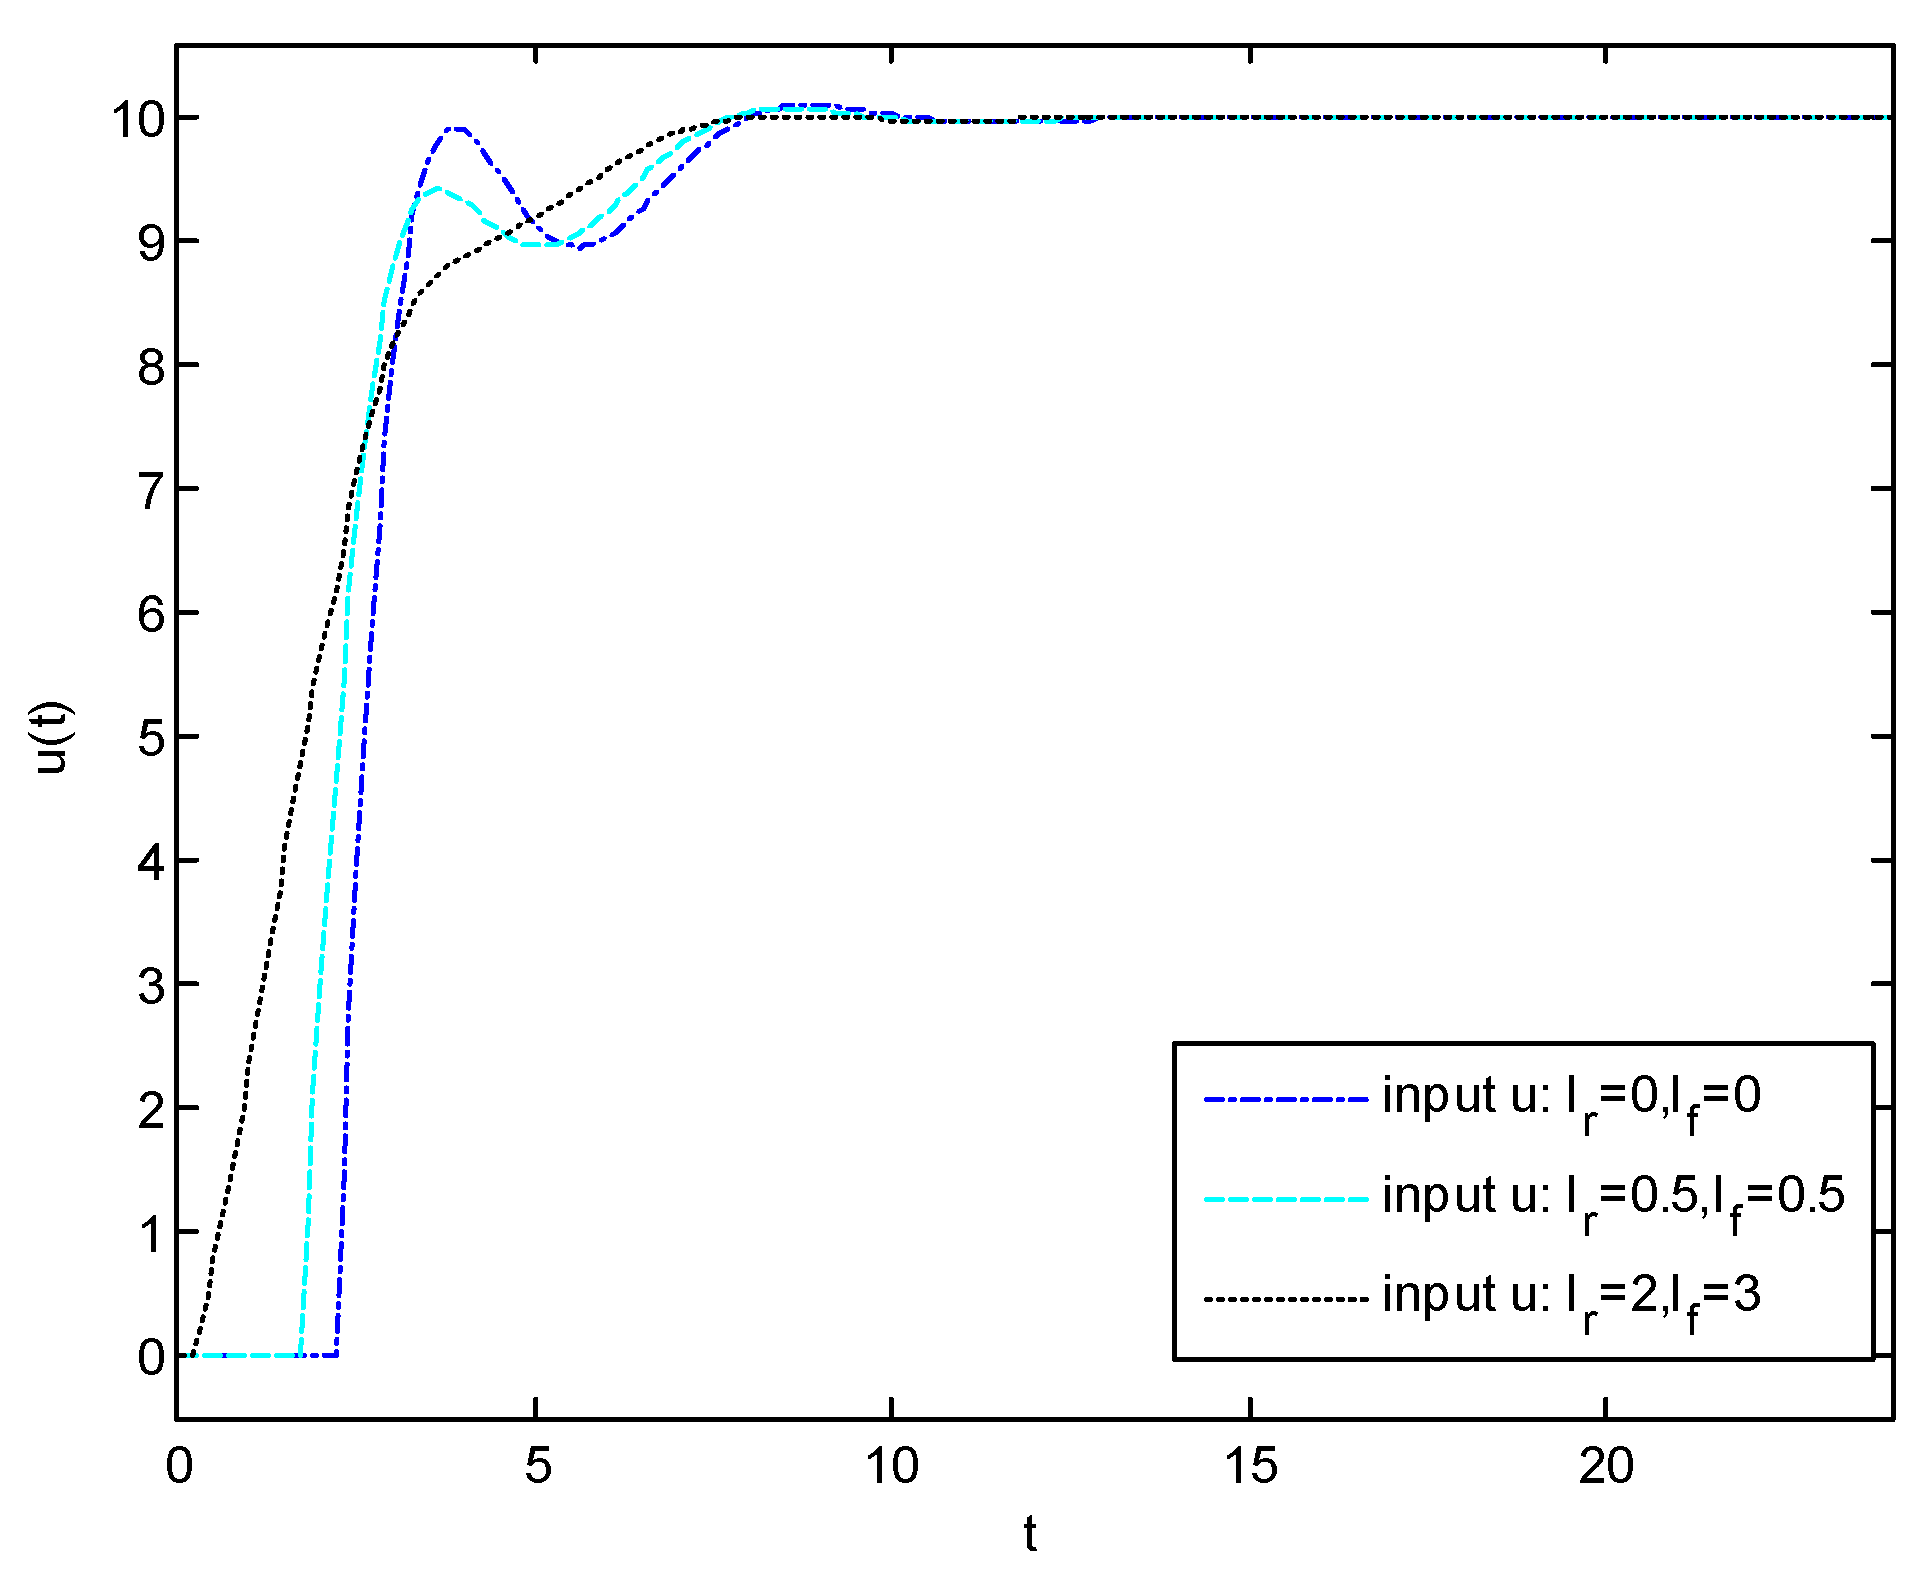
The initial conditions are chosen to be , , and , and the sampling period is . Figure 1, Figure 2 and Figure 3, respectively, stand for the output response, output tracking error, and the voltage source of the electrical circuit system when the reference input signal and the fault signal are previewable. It can be seen that the preview compensations can effectively suppress the adverse effects caused by fault signals and accelerate the response speed of the system output.
Figure 1.
The output response of the electrical circuit system with previewable signals.
Figure 2.
The output error of the electrical circuit system with the previewable signals.
Figure 3.
The voltage source of the electrical circuit system with the previewable signals.
According to calculations, the overshoot of the closed-loop system with different previewable lengths is as follows: ① when , , the overshoot is ; ② when , , the overshoot is ; and ③ when , , the overshoot is . Therefore, the longer the previewable length, the smaller the overshoot.
Figure 4, Figure 5 and Figure 6 demonstrate the output response, the tracking error, and the voltage source of the electrical circuit system without fault, respectively. The simulation results reveal that the tracking effect of the capacitance voltage to the ideal value is still remarkable under the reference input preview compensation. When the controlled system does not malfunction, the controller proposed in this article is still valid.
Figure 4.
The output response of the electrical circuit system without a fault signal.
Figure 5.
The output error of the electrical circuit system without a fault signal.
Figure 6.
The voltage source of the electrical circuit system without a fault signal.
7. Conclusions
Based on the theory of preview control and the model-following control theory of fault-tolerant control, a model-following preview controller for a class of linear continuous-time descriptor systems with actuator failures is designed in this paper. Firstly, the controlled system is transformed into a normal control system through a restricted equivalent transformation. By constructing an augmented system, the model-following problem is converted into the optimal preview control problem for the augmented system. We obtain the required controller for the original descriptor system through the preview control method. Finally, the result is applied to an electrical circuit system with actuator failures, and numerical simulation is carried out to illustrate the effectiveness of the result.
In the future, we consider extending the current results to descriptor systems with stochastic [19,32], multiple input delays, and nonlinearity, which is more challenging.
Author Contributions
Methodology, C.J.; software, C.J.; writing—review and editing, C.J.; supervision, L.L.; funding acquisition, L.L. and C.J. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the National Natural Science Foundation of China [grant number 61903130], the Higher Education Science and Technology Innovation Program of Shanxi Province [grant number 2023L235], and the Scientific Research Project of Education Department of Hubei Province [grant number Q20232204].
Data Availability Statement
No new data were created or analyzed in this study. Data sharing is not applicable to this article.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Rosenbrock, H.H. Structure properties of linear dynamical system. Int. J. Control 1974, 20, 191–202. [Google Scholar] [CrossRef] [Scilit]
- Luenberger, D.G.; Arbel, A. Singular dynamic leontief system. Econometrica 1977, 45, 991–995. [Google Scholar] [CrossRef] [Scilit]
- Tang, H.; Okubo, S. A design of model following control system for descriptor system with disturbances. IEEE Trans. Electron. Inf. Syst. 1997, 117, 1485–1489. [Google Scholar]
- Wu, S.; Okubo, S.; Wang, D. Design of a model following control system for nonlinear descriptor system in discrete time. Kybernetika 2008, 44, 546–556. [Google Scholar]
- Zhao, L.; Okubo, S. A Model Following Control System for Nonlinear Descriptor System. Energy Procedia 2012, 17, 1724–1731. [Google Scholar] [CrossRef] [Scilit]
- Abdullah, A.A. H∞ model following control of linear parameter-varying descriptor systems. Optim. Contr. Appl. Met. 2022, 43, 943–961. [Google Scholar] [CrossRef] [Scilit]
- Tian, G.T.; Duan, G.R. Robust model reference control for second-order descriptor linear systems subject to parameter uncertainties. Trans. Inst. Meas. Control 2022, 44, 658–675. [Google Scholar] [CrossRef] [Scilit]
- Gao, Y.J.; Duan, G.R. Robust model reference tracking control for high-order descriptor linear systems subject to parameter uncertainties. IET Control Theory Appl. 2024, 18, 479–494. [Google Scholar] [CrossRef] [Scilit]
- Tsuchiya, T.; Egami, T.; Liao, F. Digital Preview and Predictive Control; Beijing Science and Technology Press: Beijing, China, 1994. [Google Scholar]
- Tomizuka, M.; Rosenthal, D.E. On the optimal digital state vector feedback controller with integral and preview actions. J. Dyn. Syst. Meas. Control 1979, 101, 172–178. [Google Scholar] [CrossRef] [Scilit]
- Liao, F.; Tang, Y.Y.; Liu, H.; Wang, Y. Design of an optimal preview controller for continuous-times system. Int. J. Wavelets Multi. 2011, 9, 655–673. [Google Scholar] [CrossRef] [Scilit]
- Kojima, A.; Ishijima, S. H∞ performance of preview control system. Automatica 2003, 39, 693–701. [Google Scholar] [CrossRef] [Scilit]
- Li, L.; Liao, F. Output feedback preview tracking control for discrete-time polytopic time-varying system. Int. J. Control 2019, 92, 2979–2989. [Google Scholar] [CrossRef] [Scilit]
- Liao, F.; Takaba, K.; Katayama, T.; Katsuura, J. Design of an optimal preview servomechanism for discrete-time system in a multirate setting. Dynam. Contr. Dis. Ser. B. 2003, 10, 727–744. [Google Scholar]
- Liao, F.; Ren, Z.; Tomizuka, M.; Wu, J. Preview control for impulse-free continuous-time descriptor system. Int. J. Control 2015, 88, 1142–1149. [Google Scholar] [CrossRef] [Scilit]
- Cao, M.; Liao, F. Design of an optimal preview controller for linear discrete-time descriptor system with state delay. Int. J. Syst. Sci. 2015, 46, 932–943. [Google Scholar] [CrossRef] [Scilit]
- Li, L.; Dong, Y.; Li, Q. Output feedback preview tracking control for time-varying polytopic descriptor systems. Optim. Control. Appl. Methods 2020, 41, 521–536. [Google Scholar] [CrossRef] [Scilit]
- Gershon, E.; Shaked, U. H∞ preview tracking control of retarded state multiplicative stochastic system. Int. J. Robust Nonlin. 2015, 24, 2119–2135. [Google Scholar] [CrossRef] [Scilit]
- Wu, J.; Liao, F.; Tomizuka, M. Optimal preview control for a linear continuous-time stochastic control system in finite-time horizon. Int. J. Syst. Sci. 2017, 48, 129–137. [Google Scholar] [CrossRef] [Scilit]
- Lu, Y.; Xu, Z.; Li, L.; Zhang, J.; Chen, W. Formation preview tracking for heterogeneous multi-agent systems: A dynamical feedforward output regulation approach. ISA Trans. 2023, 133, 102–115. [Google Scholar] [CrossRef] [Scilit]
- Lu, Y.; Zhang, X.; Wang, Z.; Qiao, L. Optimal containment preview control for continuous-time multi-agent systems using internal model principle. Int. J. Syst. Sci. 2023, 54, 802–821. [Google Scholar] [CrossRef] [Scilit]
- Zhen, Z.; Jiang, S.; Jiang, J. Preview control and particle filtering for Automatic Carrier Landing. IEEE Trans. Aerosp. Electron. Syst. 2018, 54, 2662–2674. [Google Scholar] [CrossRef] [Scilit]
- Subudhi, B.; Ogeti, P.S. Optimal preview stator voltage-oriented control of DFIG WECS. IET Gener. Transm. Distrib. 2018, 12, 1004–1013. [Google Scholar] [CrossRef] [Scilit]
- Li, R.; Ouyang, Q.; Cui, Y.; Yang, J. Preview control with dynamic constraints for autonomous vehicles. Sensors 2021, 21, 5155. [Google Scholar] [CrossRef] [Scilit]
- Gao, Z.; Wu, T.; Zhang, D.; Zhu, S. Network-based gain-scheduled control for preview path tracking of autonomous electric vehicles subject to communication delays. Int. J. Syst. Sci. 2022, 53, 2549–2565. [Google Scholar] [CrossRef] [Scilit]
- Liao, F.; Jia, C.; Malik, U.; Yu, X.; Deng, J. The preview control of a class of linear systems and its application in the fault-tolerant control theory. Int. J. Syst. Sci. 2019, 50, 1017–1027. [Google Scholar] [CrossRef] [Scilit]
- Yang, D.; Zhang, Q.; Yao, B. Singular System; Science Press: Beijing, China, 2004. [Google Scholar]
- Katayama, T.; Hirono, T. Design of an optimal servomechanism with preview action and its dual problem. Int. J. Control 1987, 45, 407–420. [Google Scholar] [CrossRef] [Scilit]
- Chen, C.T. Linear System Theory and Design, 3rd ed.; Oxford University Press: New York, NY, USA, 1999. [Google Scholar]
- Lu, Y.; Liao, F.; Deng, J.; Pattinson, C. Cooperative optimal preview tracking for linear descriptor multi-agent systems. J. Frankl. Inst. 2019, 356, 908–934. [Google Scholar] [CrossRef] [Scilit]
- Dai, L. Singular Control Systems. Lect. Notes. Contr. Inf. 1989, 118, 3010–3025. [Google Scholar]
- Chalishajar, D.; Kasinathan, D.; Kasinathan, R.; Kasinathan, R. Exponential stability, T-controllability and optimal controllability of higher-order fractional neutral stochastic differential equation via integral contractor. Chaos Solitons Fractals 2024, 186, 115278. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).