Systematic Review

Mobile Robot Localization and SLAM: A Critical Review of Sensors, Multi-Sensor Fusion, and Neural Representations


by
José Miguel Guerrero Hernández
*,
Rodrigo Pérez-Rodríguez
,
Juan S. Cely
,
Esther Aguado
and
Francisco Martín Rico
Intelligent Robotics Lab, Universidad Rey Juan Carlos, EIF, 28943 Fuenlabrada, Spain
*
Author to whom correspondence should be addressed.
Robotics 2026, 15(8), 142; https://doi.org/10.3390/robotics15080142

Submission received: 1 July 2026 / Revised: 21 July 2026 / Accepted: 23 July 2026 / Published: 28 July 2026
(This article belongs to the Special Issue State of the Art in Mobile Robot Localization)

Abstract

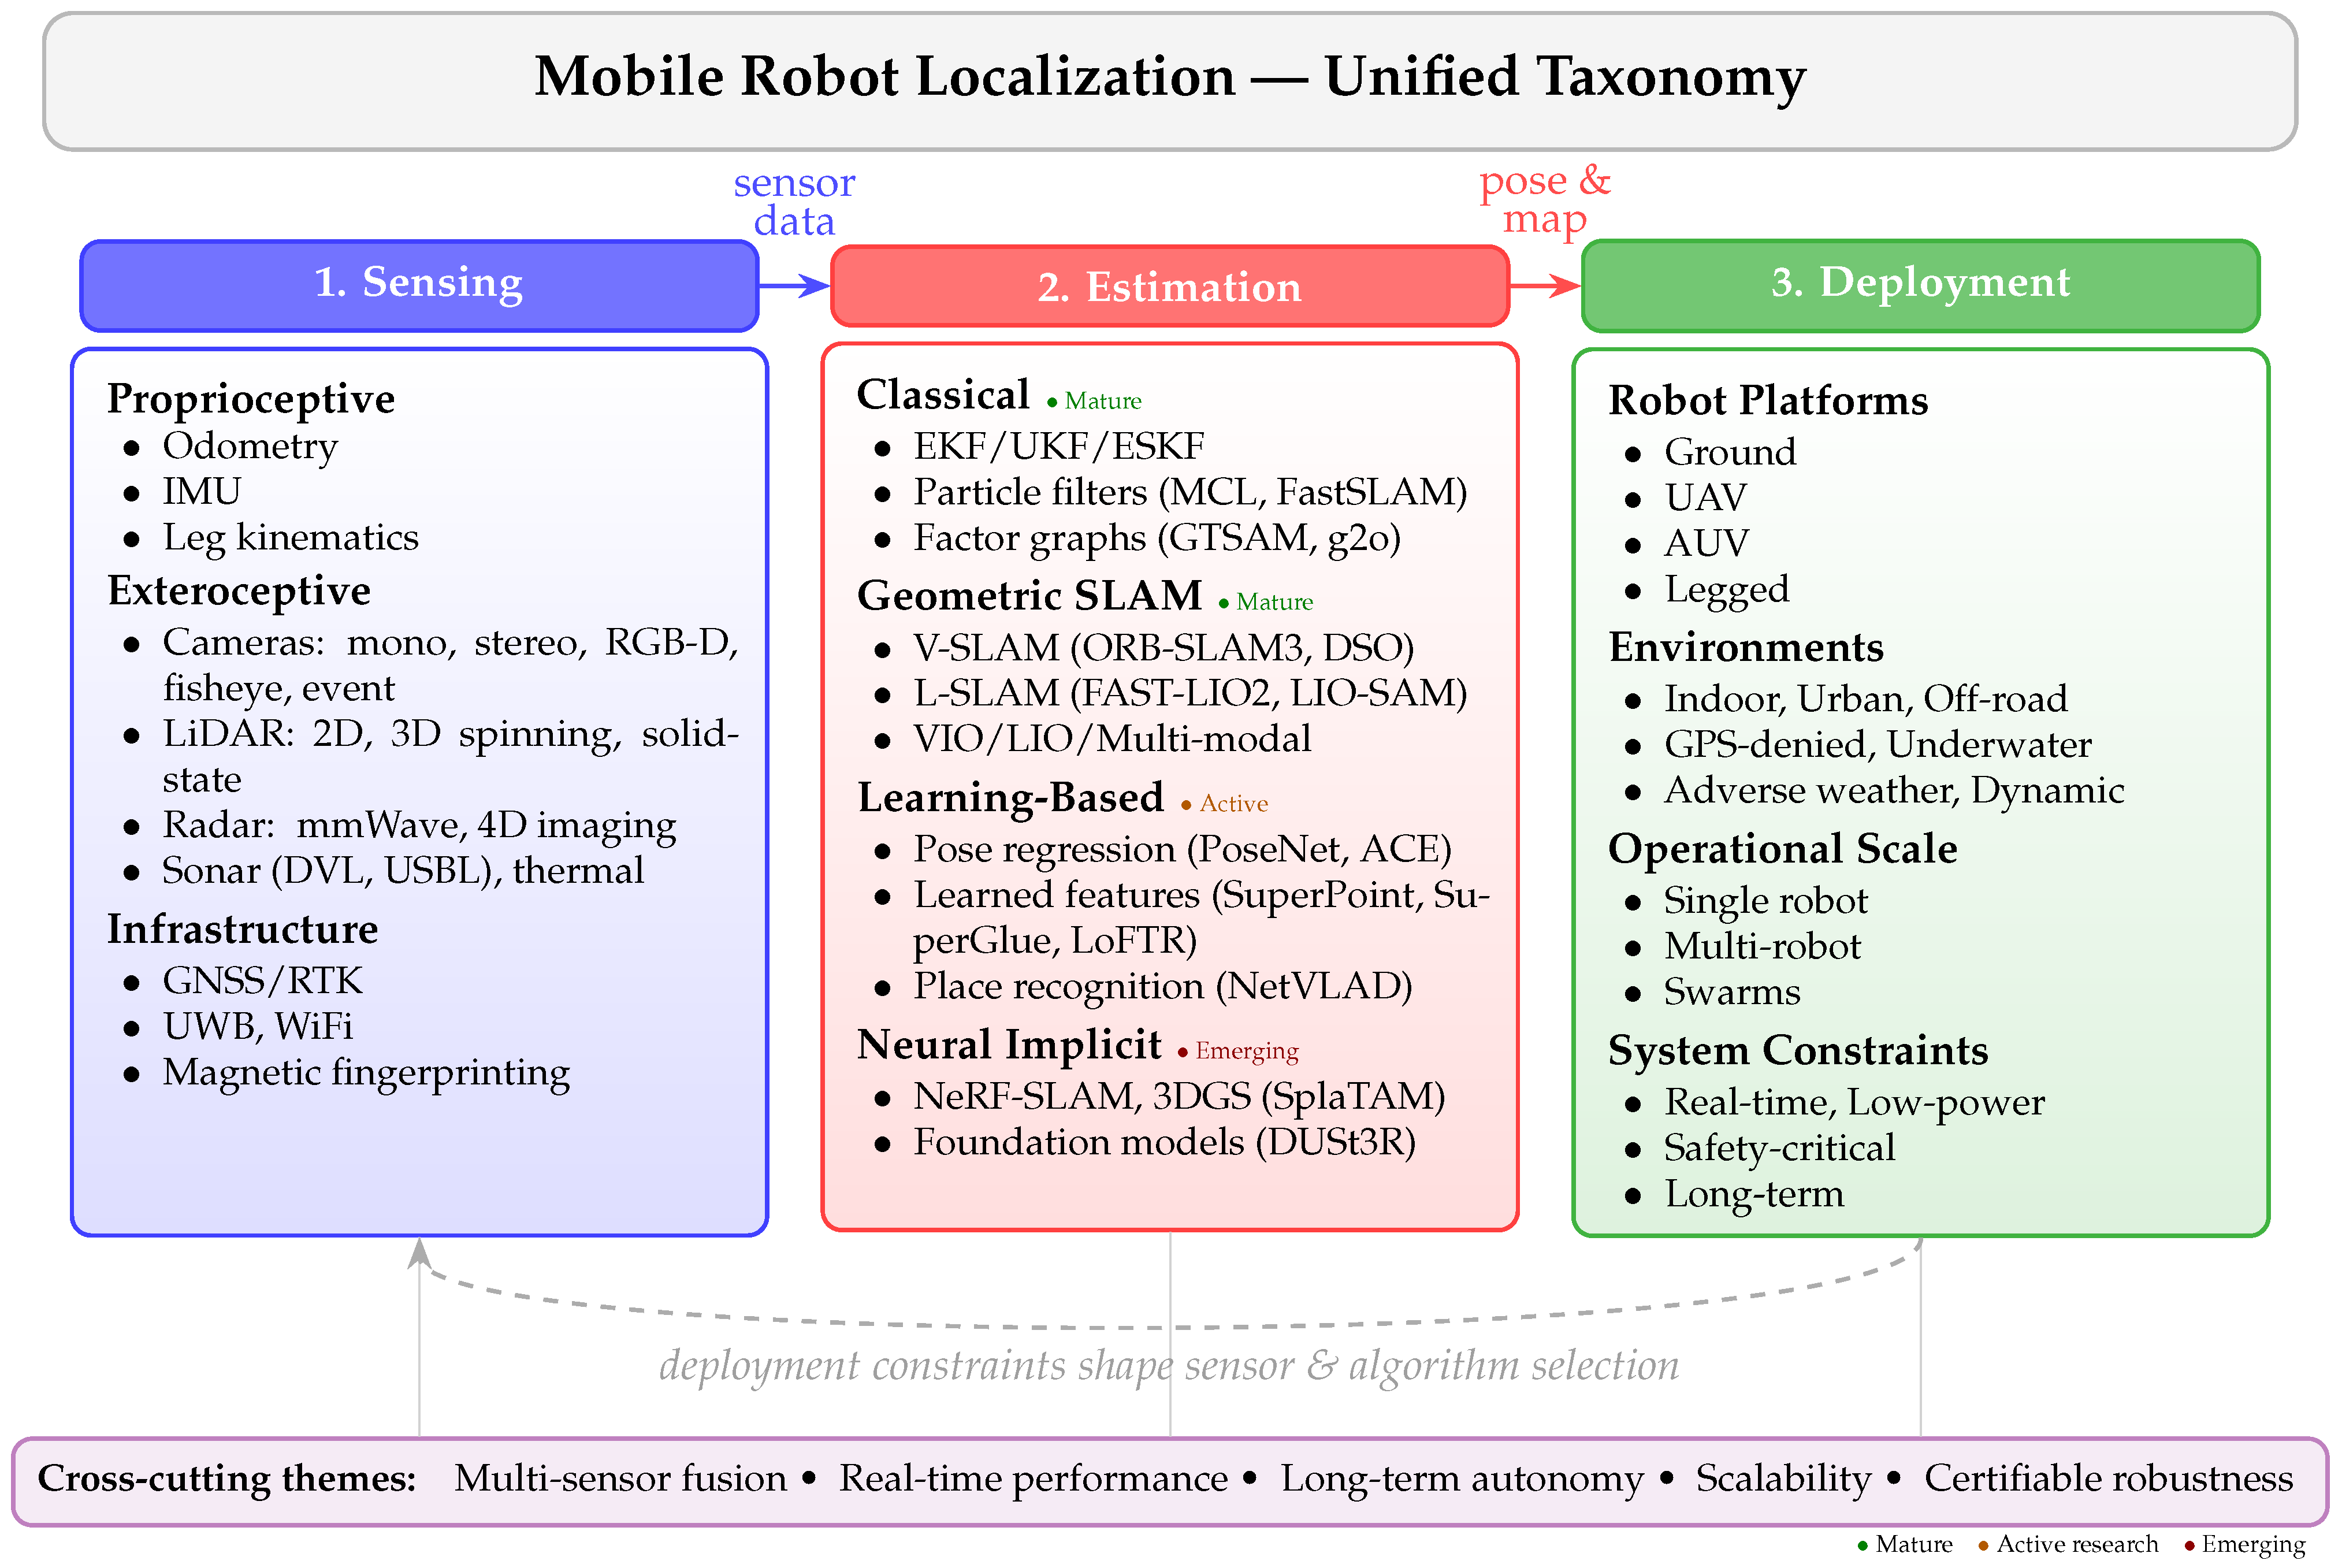
Accurate and robust localization remains the fundamental bottleneck for truly autonomous robotic systems, despite decades of progress in probabilistic estimation and SLAM. This paper provides a critical and comprehensive review of mobile robot localization across sensing modalities, estimation paradigms, and deployment domains, covering ground, aerial, and underwater platforms. Beyond a descriptive survey, we explicitly analyze the limitations and trade-offs of existing approaches. We introduce an updated taxonomy that spans classical proprioceptive and exteroceptive sensors, emerging technologies such as 4D imaging radar and event cameras, and infrastructure-based positioning systems including GNSS and Ultra-Wideband. We revisit the evolution of localization algorithms, from Bayesian filtering techniques (EKF, UKF, and particle filters) to modern graph-based SLAM frameworks and tightly coupled multi-sensor fusion systems. Particular emphasis is placed on the recent paradigm shift toward learning-based and neural implicit approaches, including NeRF-SLAM and Gaussian Splatting, highlighting both their transformative potential and their current impracticality for real-time deployment. Unlike previous surveys, this work provides a unified cross-domain perspective while critically examining scalability, robustness, computational cost, and real-world deployability. We identify key unresolved challenges, including long-term consistency, operation in degraded environments, and the integration of semantic understanding into localization pipelines. Furthermore, we propose standardizing evaluation metrics with a formal Trajectory Completeness formulation to expose tracking brittleness. Finally, we outline future research directions toward resilient, certifiable, and truly autonomous localization systems, emphasizing the critical transition from passive estimation to Active SLAM in unstructured environments.
Keywords: mobile robot localization; simultaneous localization and mapping; SLAM; deep learning; sensor fusion; autonomous navigation; visual odometry; LiDAR; neural radiance fields; multi-robot systems mobile robot localization; simultaneous localization and mapping; SLAM; deep learning; sensor fusion; autonomous navigation; visual odometry; LiDAR; neural radiance fields; multi-robot systems