


Abstract
This paper addresses the problem of stabilizing an inverted pendulum actuated by a reaction wheel, a system relevant for robotic balancing platforms and aerospace applications. The study compares several state-space representations of the system and examines their implications for controller synthesis and parameter identification. A unified nonlinear model formulation is introduced, enabling a structural Lyapunov-based robustness analysis that reveals how variations in the gravitational gain affect closed-loop stability. Control strategies based on pole placement and Linear Quadratic Regulator (LQR) design are implemented and compared across the different representations. The analysis highlights a robustness–fidelity trade-off between model complexity and sensitivity to parameter uncertainty, providing insight that extends beyond the specific laboratory setup. Theoretical results are validated on a real laboratory platform. The controllers are evaluated in both upright and downward equilibrium configurations, and the influence of parameter shifts is assessed experimentally using global identification and performance indices. The work offers general modeling and robustness guidelines for reaction-wheel-based stabilization systems and related underactuated nonlinear mechanisms.
1. Introduction
The reaction wheel pendulum (RWP) system was first introduced to robotics in [1] as a more complex form of the inverted pendulum, featuring an additional degree of freedom. In certain studies [2], it is also referred to as the Inertia Wheel Pendulum (IWP). The system is of particular interest from the perspective of control theory. More precisely, it represents an example of a nonlinear underactuated system that is feedback-linearizable, in contrast to the well-known cart-pendulum system [3,4]. Recently, it has been formally shown that although the RWP can be linearized, the mechanical structure of the equivalent linear form cannot be preserved [5]. It is also worth noting that, although the original mechanical structure of the RWP is relatively simple, it can nevertheless be regarded as a benchmark system that enables the development of analysis and control synthesis methods characteristic of more complex systems encountered in practice. For example, such a system can be used to support the balancing control of two-wheeled vehicles [2,6], where the platform is required to move while maintaining an almost vertical body position. The dynamics of the reaction wheel can also serve as a foundation for the motion control and stabilization of satellites [7,8] or spacecraft attitude [9].
Melchiorre et al. [10] presented the design and control of a spherical rover driven by a hybrid pendulum–control moment gyroscope (CMG) mechanism, demonstrating that combining barycentric offset actuation with gyroscopic torque generation significantly enhances obstacle-climbing capability and overall agility. Huang et al. [11] developed an advanced stability and path-tracking control system for a self-balancing bicycle equipped with a reaction wheel, introducing an adaptive equilibrium point gradual algorithm (AEPGA) that reduces energy consumption while maintaining robust balance under varying dynamic conditions. In parallel to these adaptive strategies, Wang et al. [12] developed an adaptive backstepping controller for uncertain nonlinear systems affected simultaneously by input and state quantization, guaranteeing uniform boundedness and robustness despite severe information loss. Although not focused on momentum-exchange systems, this result illustrates how modern adaptive nonlinear control increasingly addresses realistic nonidealities —such as quantization or limited sensing—that also arise in practical RWP setups. Earlier foundational work by Pyrkin et al. [13] proposed an adaptive stabilization approach for a reaction wheel pendulum under full parametric uncertainty, enabling on-line adjustment of controller parameters without prior system identification. These studies collectively illustrate the progressive integration of adaptive and hybrid control strategies in systems that exploit angular momentum exchange for stabilization and locomotion. In their approach, the system parameters were identified online using an adaptive regression-based estimation method, differing from traditional least-squares techniques by enabling real-time parameter updates without prior model knowledge.
Modern nonlinear control of underactuated mechanical systems increasingly builds on energy-based principles. Recent contributions include improved energy-shaping and passivity-based stabilization methods, where Interconnection and Damping Assignment Passivity-Based Control (IDA–PBC) is extended to provide robustness guarantees and enhanced disturbance handling [14]. Passivity-oriented and energy-shaping approaches have also been applied to aerial manipulation and payload transport, demonstrating the relevance of energy-based techniques for systems structurally similar to the RWP [15]. Relatedly, Guerrero-Sánchez et al. combine energy-based outer-loop design with an LMI-based nonlinear attitude controller for a quadrotor transporting a cable-suspended payload, showing that energy-shaping concepts can effectively reduce payload oscillations in three-dimensional motion [16]. Another recent direction employs nonlinear methods for robust control of underactuated systems. Qiu et al. [17] proposed a hierarchical nonlinear controller for a dual-quadrotor suspended transport system, integrating the effects of all degrees of freedom into the cost functional and guaranteeing closed-loop stability via Lyapunov analysis, with ADRC used in the inner loop for disturbance rejection.
Beyond adaptive or energy-based approaches, several recent works have focused on the design and comparison of classical control schemes for the RWP, pointing out practical difficulties [18]. In the paper [19], the authors presented the mechanical design, mathematical modeling, and stabilization task of the RWP control system. The behavior was assessed in a simulation and using a real-world experiment. Two control algorithms—cascaded proportional–integral–derivative (PID) controller and the state feedback using linear quadratic regulator (LQR) and Kalman filter (KF)—were compared. Better control precision was provided in this case by PID, while LQR enabled greater robustness to noise and disturbances. Previous studies have examined actuator saturation in detail, including advanced compensation strategies such as static anti-windup with shifted equilibrium points [20]. These results underline the practical relevance of this phenomenon and motivate our interest in understanding how different model structures influence control effort.
A complementary issue to control design—one for which a proper model can be an essential factor—is system identification. Among the available identification approaches, nonparametric methods can be used to extract general information about the system, including its expected order, stability properties, or type (e.g., minimum phase, oscillatory) [21,22]. In contrast, parametric methods lead to estimation of the numerical parameter values based on a regression representation. One of the fundamental approaches of parametric identification is the least squares (LS) method [23]. Recent advances in optimization theory also provide additional tools that may be employed when the identification or tuning criterion admits a quadratic or strongly convex structure. For instance, distributed optimization techniques based on nonlinear small-gain arguments have been developed for multiagent systems [24], offering robustness guarantees for strongly convex objectives under partial gradient information. Likewise, autonomous optimization schemes using modified gradient-flow operators [25] provide global asymptotic stability results for interconnected nonlinear systems (which admit a unique globally asymptotically stable equilibrium corresponding to the optimizer) by combining singular perturbation analysis with input-to-state stability theory.
These results are promising from a theoretical perspective; however, they address classes of problems substantially different from the parameter identification setting considered here. In particular, the contributions in [24,25] focus on feedback-based convex optimization in multiagent or multi-time-scale scenarios, and the reported validations are primarily simulation studies. As verified in [24] (Section VII) and [25] (Section IV), the proposed algorithms are demonstrated on numerical examples rather than hardware experiments. For clarity and transparency, the identification procedure used in this work relies on the classical LS formulation, whose regression structure and normal-equation solution are stated for each RWP model investigated in the paper.
ResearchGap, Motivation and Contribution
Although the reaction wheel pendulum has been extensively used as a benchmark system, prior studies typically adopt a single state-space representation and do not investigate how alternative modeling structures influence identification quality, robustness, or closed-loop performance. In particular, the literature lacks a systematic comparison of nonlinear representations, analysis of how the distribution of nonlinear terms affects the admissible stability region, and assessment of how uncertainty in the gravitational gain propagates through different model structures. This paper addresses these shortcomings by providing a unified nonlinear framework, a parameterized Lyapunov robustness analysis, and an experimental comparison of three model variants. The contributions listed below directly address these open issues.
The main contribution of this paper can be defined as follows:
- Systematic comparison of nonlinear model representations of the reaction wheel pendulum (RWP), including an assessment of their local linearization properties—Section 2.1, Section 2.2 and Section 2.3.
- Introduction of a generalized model structure with an embedded nonlinear function , capturing both the RWP dynamics and a wider class of similar nonlinear systems—Section 2 (Proposition 1).
- A complete nonlinear identification methodology for all model variants, based on the regression structure, enabling globally valid parameter estimation directly from experimental data—Section 2.4.
- A Lyapunov-based stability assessment that highlights how variations in the gravitational gain influence the robustness of the considered model structures—Section 3.
- A comprehensive comparative study, evaluating the practical behavior, control performance and applicability of all considered models under real-world operating conditions on the RWP platform—Section 4.
The paper is organized as follows. Section 2 contains the description of the RWP modeling approaches, with the proposed generalized nonlinear system structure, and its theoretical analysis. The theory about the parameter identification process can also be found there. In Section 3, an overview of a control system is included. Linearization at the equilibrium point, the state feedback method, and feedback gain selection methods are described. Lyapunov stability analysis for the system structure used is also considered. Section 4 contains experimental results obtained from the RWP system under the real-world conditions. The stabilization results at two equilibrium points for the applied approaches are presented, along with detailed conclusions derived from these results. The system performance is evaluated graphically and based on integral quality indices. A summary of the paper and future work perspectives are included in Section 5.
2. Nonlinear Modeling of the Reaction Wheel Pendulum
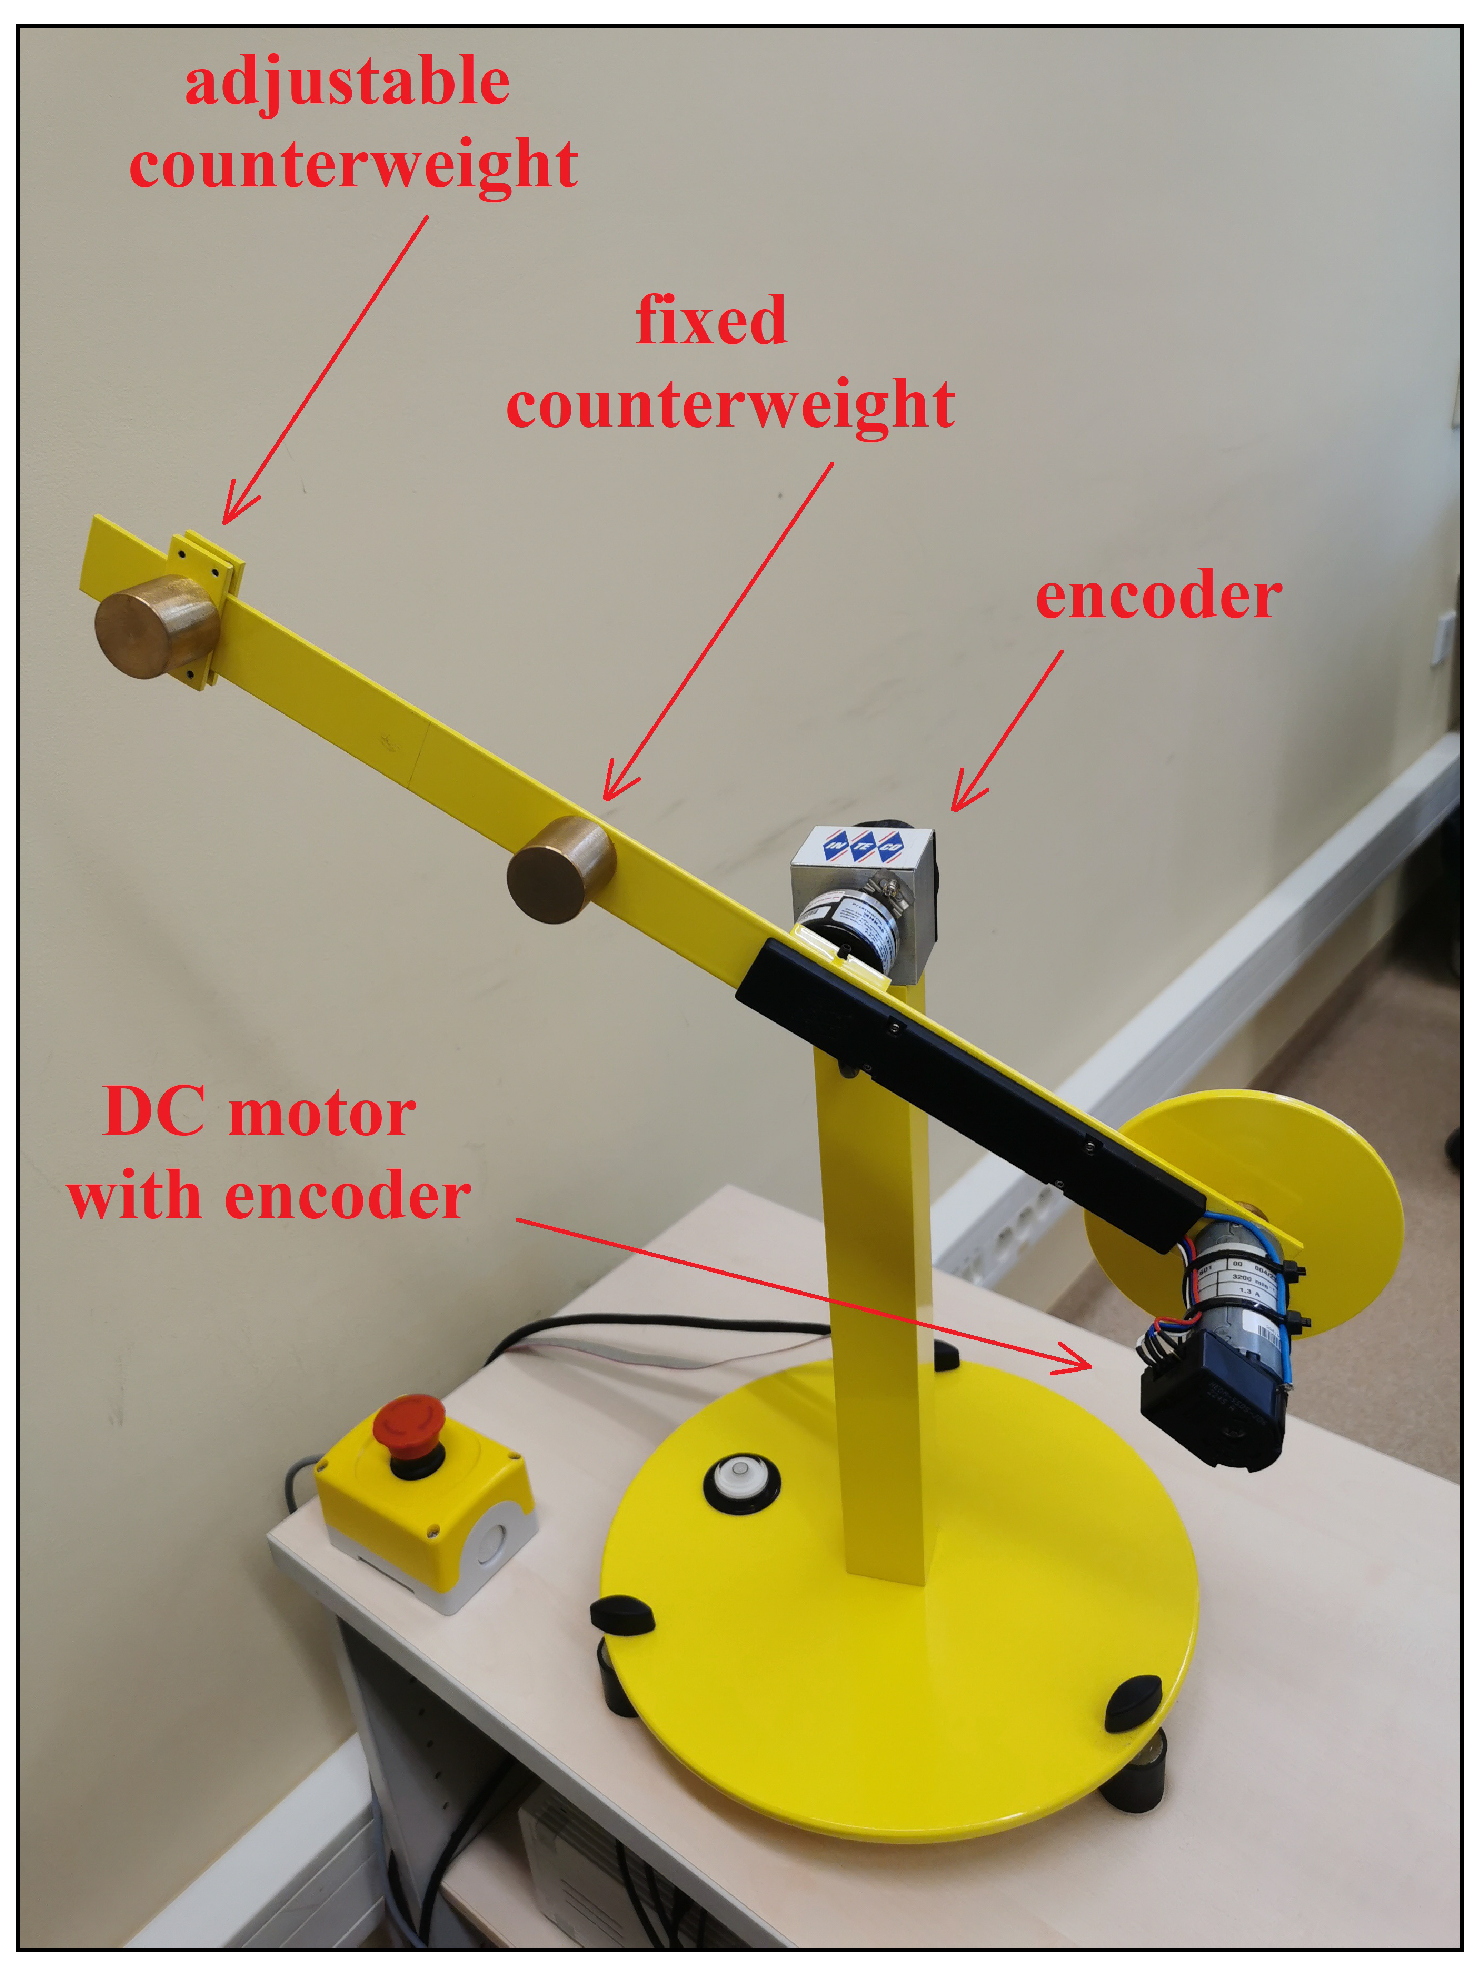
This section describes the most important aspects of modeling an RWP system along with presenting the parameters for the laboratory setup used in the experiments. The experiments were carried out on a Reaction Wheel Pendulum platform (Reaction Wheel Pendulum, INTECO, Kraków, Poland) using MATLAB R2022a/Simulink (The MathWorks, Natick, MA, USA) with real-time execution via RT-CON (INTECO, Kraków, Poland). A photo of the laboratory setup with the most important components marked is shown in Figure 1.
Figure 1.
Photo of the laboratory control plant.
The system exhibits two equilibrium points: a stable oscillatory equilibrium in the lower arm configuration and an unstable one in the upper position. It is worth noting that the RWP setup includes an adjustable counterweight, enabling modification of both the system’s moment of inertia and the gravity moment. In the case when the center of mass is located above the axis of rotation, the upper position corresponds to a stable equilibrium point. Furthermore, by aligning the center of mass with the axis of rotation, the RWP can be fully balanced and stable in any position (each pendulum angle is the equilibrium point).
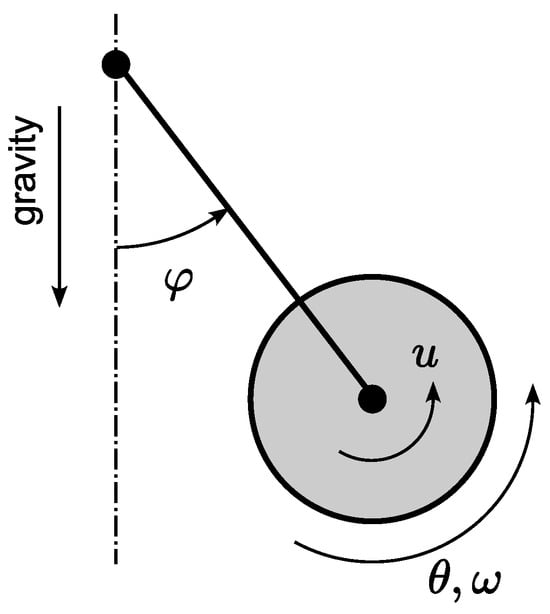
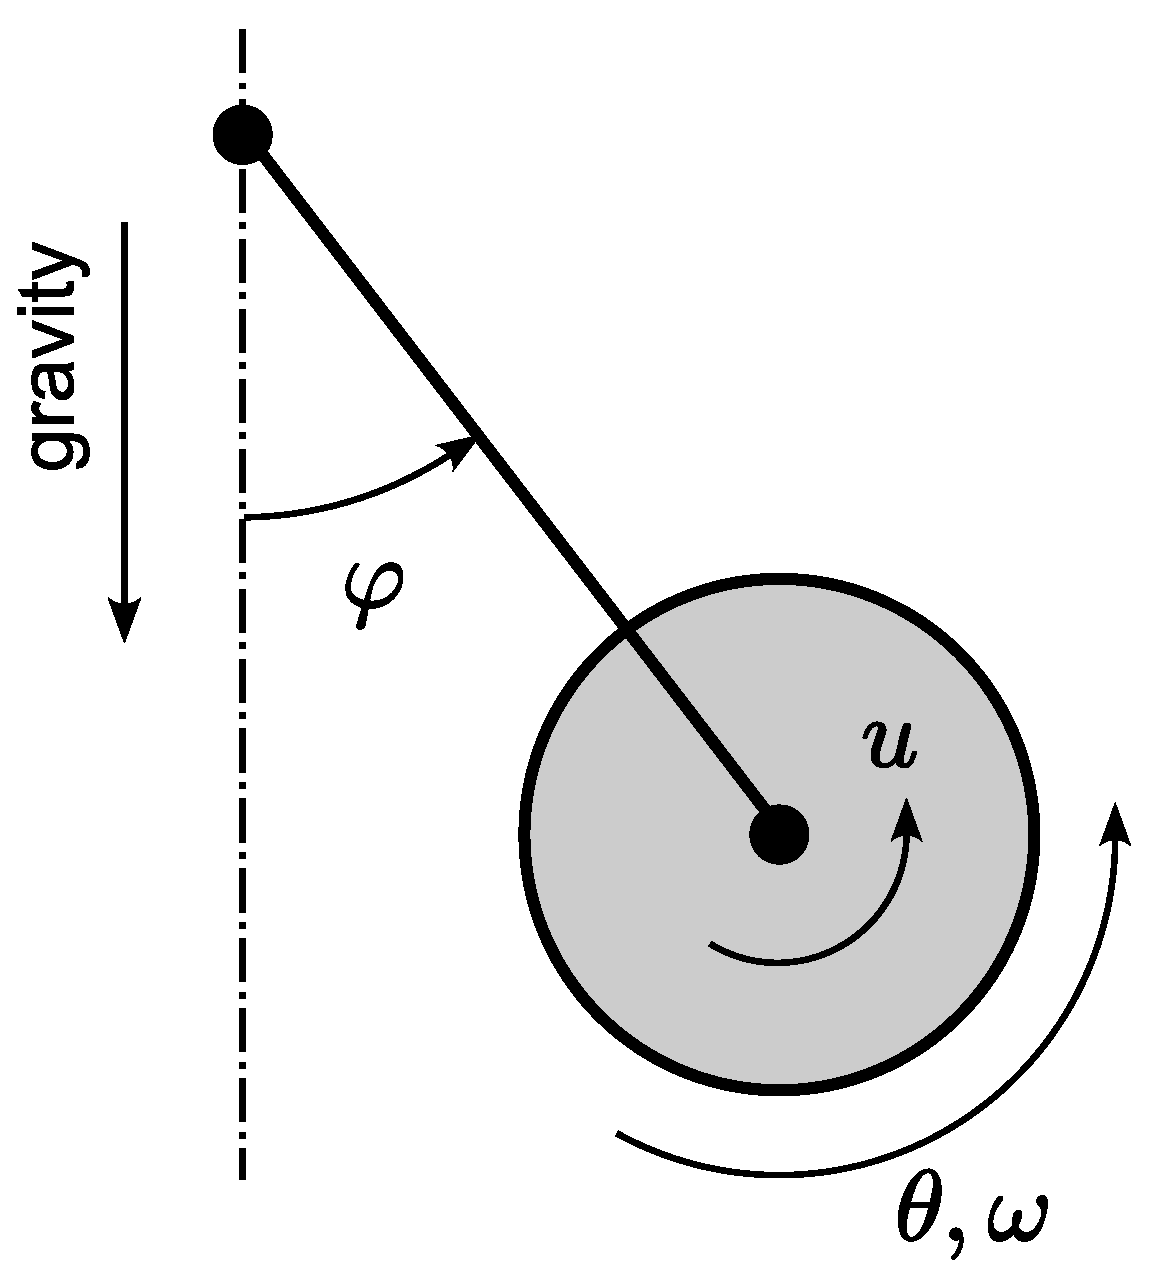
The configuration space of the system is defined on two-dimensional torus, namely , and the configuration is represented by two variables, pendulum angle and flyweel angle , as shown in Figure 2. The flywheel is actuated by a DC motor, while it is assumed that an electromagnetic time constant is negligible with respect to the mechanical constant of the overall system. Such a simplification makes it possible to model the pendulum as a second-order mechanical system.
Figure 2.
Diagram of the RWP system.
In the following sections, various approaches to modeling the RWP system will be examined and compared. This comparison highlights the trade-off between model fidelity and analytical tractability, which motivates the selection of a specific model depending on the control design objective. One of the aspects considered in these models will be their equivalence to a linear system, achieved through a transformation of the system state and input.
2.1. Full Nonlinear State-Space Model with Coupled Dynamics
Firstly, the physical model with two output signals (pendulum angle and flywheel velocity), according to [26], is presented:
. The system parameters are given as follows: is the pendulum moment of inertia, m is the pendulum mass, l is the center of mass value, is the DC motor moment of inertia, g is the gravitational acceleration, and are the torque and electrical constants, respectively, R is the DC motor armature resistance, is the friction coefficient in the pendulum axis, and is the friction coefficient in the motor axis. The input signal is the voltage for the DC motor, and two signals are considered as outputs, the pendulum arm angle rotation and the DC motor velocity . The investigated model represents a single-input multiple-output (SIMO) system. In further considerations, the explicit dependence of variables on time will be omitted, i.e., .
Using a state-space representation one can find a specific form of the nonlinear system
where
where the state vector is defined as , and is an analytic function with the domain . The form of the dynamics shown suggests that a significant part of the RWP is linear. Hence, it is possible to use model (2), which is free of singularities and similar to a linear time-invariant (LTI) system, the only difference being that matrix is state-dependent. Note that the second column of is zero since the wheel angle is a cyclic coordinate; i.e., it does not influence the dynamics. This results in an integrating mode , but does not affect controllability of the states relevant for stabilization. We formally discuss this issue in Appendix A.
To facilitate the analysis of system (2) more thoroughly, the dimension of the state space can be reduced. This is because the dynamics of (2) are invariant with respect to the configuration . Since defines trivial linear dynamics, omitting the state does not restrict the analysis—it is not subject to control in the task of pendulum stabilization. Therefore, the state vector is reduced to three elements: .
Proposition 1.
The system (2) with the structure
with as a smooth function such that
is feedback-linearizable at a neighborhood of the origin when the parameters , ( and ) satisfy
Proof.
Let us rewrite the drift term (2) as
where
is a matrix with constant coefficients and with
The input vector from model (2) is treated as a constant control vector field .
According to the nonlinear control theory, a nonlinear SISO system
can be fully and (at least) locally linearized using the state space and input transformations when particular distributions of vector fields satisfy certain properties [27,28]. In the considered case, in which the dimension of the state space is , we take into account the following distributions:
In order to find vector fields that span these distributions, we calculate the corresponding Lie brackets:
where . To denote the i-th component of a vector resulting from some expression, the notation is used. Since and are constant vector fields, one can easily conclude that the distribution is involutive for any .
Next, we deal with the dimension of the distribution . By evaluating the detailed form of the vector fields in (11), we obtain the following:
Investigating the number of linearly independent vector fields in , one can find that its dimension is maximal and equals to the dimension of the state space when the following condition is satisfied:
Recalling the assumption (5) and the definition (9) it follows that in a neighborhood of the origin, that is, for , when (6) holds. Since is involutive, that means that the system (2) with (4) is locally equivalent to a three-dimensional linear system in Brunovsky’s form using a smooth state and input maps. □
Based on the result of the proposition, we can consider the RWP dynamics (2) with (3) in reduced form. To be more specific, we investigate (4) taking into account the following parameters: , , , , , , , the function .
In such a case, the condition (13) can be significantly simplified, since , as follows:
This result implies that the three-dimensional model of the RWP, including dissipative terms, can be transformed into a linear form for any , except at the isolated points , where k is an odd positive integer. Moreover, it shows that the dissipative terms do not affect this linearizability condition.
To remain consistent with the variants of RWP dynamics discussed in this paper, we rewrite (1) and consider it as model :
which is a reformulation of the model (4), into drift input form, with the parameters defined above. This model explicitly incorporates frictional effects and the separate dynamics of both the pendulum arm and the reaction wheel. It preserves the full nonlinear dependence on and is valid over the same operating range as the reduced nonlinear model.
2.2. Input–Output Formulation (Third-Order Model)
Although the previous model provides a detailed description of the system dynamics through two separated output variables—the pendulum angle and the wheel velocity—it may be desirable, for some theoretic analyses such as controllability and identifiability studies, to derive a single input–output equation that directly relates the input signal (voltage) to the controlled output (pendulum angle). For example, such a representation can be used in the active disturbance rejection control (ADRC) approach [29], or it is convenient to obtain the canonical state-space representation. This section presents the derivation of such an input–output model.
One can transform the model (15) through obtaining the derivative of the first equation. The result is a third-order equation depending on , , , and also and . In order to eliminate two last terms, let us solve the original dependencies:
After combining the above scalar formulas, the following input–output model is obtained, denoted as :
The parameters of this model are marked as , , and . They arise from transformation to Brunovsky’s form; consequently, each represents a specific algebraic combination of inertial, damping, gravitational, and electromechanical terms, and does not admit a separate physical interpretation. The non-casual term appears for the same reason: transformation to Brunovsky’s form leads to Equation (16) containing the derivative of the input. This is a standard and fully causal representation, mathematically equivalent to the original state-space model.
Equation (17) can be readily simplified to the following form after applying integration on both sides:
A more compact notation for integration will be used henceforth: . Without loss of generality, the integration constant , arising from the initial conditions, may be assumed to be zero.
By choosing the state vector as , the system (18) can be expressed in the form corresponding to (7), where
Remark 1.
Equation (17) preserves the input–output behavior but does not explicitly encode the internal dynamics. Therefore, feedback linearizability as a full state-space property (proved via the distributions (10), (12)) is not strengthened by re-deriving conditions in the input–output form. In particular, for the presented system one only recovers the external facts that the relative degree with respect to u equals (since ) and that the matching condition merely cancels the coefficient of u in without affecting r. Consequently, the state-space condition (6) remains the decisive one, and repeating the derivation on the model does not introduce additional constraints.
2.3. Simplified Pendulum–Wheel Model (Second-Order Dynamics)
In the literature, a simpler approach to modeling the RWP can be found, based on second-order dynamics [30,31]. Following this idea, we consider the model , obtained by simplifying model (15) through treating the term dependent on the flywheel angular velocity as a disturbance. As a result, the considered dynamics neglect a proportion of dissipative terms and higher-order coupling effects, and retains only the essential nonlinear pendulum dynamics, including the friction which affects motion of the pendulum:
where , , , and is treated as the disturbance signal. Under stabilizing control of the pendulum, the wheel velocity remains bounded, and the term represents the influence of the reaction wheel on the pendulum acceleration. It can be treated as a bounded disturbance, provided that , where is small relative to the dominant pendulum dynamics. Under this condition, the internal dynamics of the reaction wheel do not compromise the qualitative behavior of the controlled output and can be safely neglected in the control design.
The state-space model in the structure (7), where , is presented below:
The term is not directly included in the control system synthesis.
Remark 2.
Consider the control-affine system
where
with the state and output . Then
Therefore the vectors and are linearly independent for all states:
Consequently, the distribution has rank at each point, while the one–dimensional is involutive trivially. As a result, this single-input system structure is feedback-linearizable if it is Kalman-controllable. By the standard state-feedback linearization theorem, the system is globally feedback-linearizable to Brunovsky’s form.
An explicit global feedback is the standard for such a system form
under which the (identity) coordinate choice yields
i.e., a globally linear double integrator. In particular, for the output the relative degree equals globally.
2.4. Parameter Identification
A way to determine the values of the model parameters before the controller synthesizes may be to use structural identification methods. For the purpose of parametric identification, the form of linear regression for the models under consideration can be written
where is the regression output vector, is the regression matrix (or vector for the SISO case), is the parameter vector, and is the disturbance (i.e., noises, unmodeled part) vector.
In this work, the estimated parameter vector is obtained using the ordinary Least Squares (LS) estimator, which minimizes the quadratic cost function
The minimizer of J follows from the normal equation, which characterizes the ordinary LS solution:
where and are the regression matrix and measurement vector, composed of regressions for N consecutive measurement data.
Remark 3.
For the proper identification process, the regression set (25) should fulfill the persistent excitation condition
where is the initial time, is the experiment horizon, is some positive, small-enough constant, and is the identity matrix. This ensures that the input signals provide enough excitation to guarantee unique parameter convergence.
The minimal eigenvalue of the information matrix must satisfy . Because has the smallest parameter set and regression dimension, it requires the least excitation to meet this condition, improving the conditioning of the identification problem compared to and .
Convergence properties follow from standard LS theory and depend on the smallest singular value of ; this leads to the error bound.Throughout the paper, denotes the Euclidean 2-nd norm of an vector, and denotes the spectral (or induced 2-norm) of a matrix :
where C is some positive and small-enough constant value. Considering the regression model (25) and an estimator such that (29) is fulfilled, and defining the residual term , one can obtain
If and (i.e., each ) is bounded, then in norm.
Remark 4.
Assume least squares with full column rank, . Then
where denotes the smallest singular value. Including the feature in the regression moves the structured term from into , thus reducing (to noise only) and tightening the bound. Omitting in the model leaves a deterministic component in and induces a bias:
The exemplary theorem on the convergence of parameters can be supported by the publication [32], where the authors analyzed an adaptive control approach.
The regression forms and parameter vectors for the considered models are presented in detail in Table 1. For notational clarity, the state-space description is not used here. Note that using the presented forms, the model parameters are estimated globally, independently of the actual work point, assuming a uniform dynamic behavior over the entire range of motion. When higher-order derivatives are not directly measurable, a State Variable Filter (SVF) is used to reconstruct the required signals [23]. The SVF transfer function is given by , where i and n denote the derivative and system orders, respectively, and is the filter time constant. Although the underlying model is nonlinear in the state variables, the regression remains linear in the parameters, so the persistent excitation condition and minimal eigenvalue criterion (see Remark 3) still apply.
Table 1.
Regression models for the RWP system representations considered in this paper.
3. Control System Design
3.1. State-Space Representations and Linear Approximations of the Models
For classical state feedback design, the linear form of the state-space representation is preferred. The nonlinear system (2) described by a differentiable drift function and the input vector filed can be approximately linearized in the neighborhood of an equilibrium point , provided that the function is continuously differentiable (i.e., of class ) with respect to both the state and input variables. This permits the use of a first-order Taylor expansion to approximate the dynamics of system (2) locally as
where , , and are the state vector and system input at the equilibrium point.
The state matrix of the linearized system (7) can be obtained as follows:
while the output equation is linear and can be described by
The linear approximation forms of the models considered in this paper are presented in Table 2. In this consideration, the following derivative of the nonlinear function is used
In addition, we introduce the following definition: .
Table 2.
Matrices in the linear state-space representation for the models considered.
Remark 5.
The term in all considered models can be written as or via with . In the considered models local linearization via Taylor series around an equilibrium introduces a truncation error , bounded by for . This ensures an explicit region of intended fidelity for the simplified model and clarifies when controller performance predictions remain valid.
3.2. State Feedback in the Vicinity of the Equilibrium Point
For the linear approximation of the system at the equilibrium point (matrices given in Table 2), the control law is given by
where is the state feedback gain vector.
It can be assumed that stabilization is considered only at the equilibrium point in which (lower and upper arm position). Furthermore, the output angle normalization to zero value was implemented at both equilibrium points (see Remark 7 in the next section). For this reason, the input signal in steady state is equal to zero and the control law (37) can be simplified to the form
Remark 6.
It is noteworthy that the stabilization task depends on the model and the states included in (38). Although the main control objective remains the same for each model—namely, the stabilization of the pendulum angle φ—for model it is possible to extend the control objective to include stabilization of the flywheel velocity. This possibility is not directly available for models and , since ω is treated as an auxiliary control variable used solely to maintain stabilization of the pendulum angle. Consequently, the internal dynamics governing the evolution of ω are not asymptotically stable.
The essential step in the control design is a proper parameterisation of the state matrix of the approximated linear closed-loop system, which can be obtained as follows:
Approaches for Obtaining the Feedback Gains
- Pole placement (PP)—this method designs a state feedback controller by assigning the eigenvalues of the closed-loop system state matrix to desired locations in the complex plane to achieve specific dynamic characteristics. In practical solutions, the one multiple value is often considered:where is the desired real eigenvalue ( is the closed-loop system pole), and is the identity matrix.
- LQR approach—this method determines the optimal state feedback gain by minimizing a quadratic cost function that balances control effort and state deviation in linear time-invariant systems.The integral quality index is considered:where is the cost matrix of the state variables, and is the cost of the control signal.The optimal state feedback gains are obtained using the formulawhere is the covariance matrix, determined by the solving of the Algebraic Riccati Equation (ARE).
Proposition 2.
Consider the closed-loop system
where is a vector of small enough residual nonlinear terms, and the given assumptions are fulfilled:
- The nonlinear function has the property ; then is the equilibrium point of closed-loop system;
- The controller synthesis ensures that the linear approximation of the closed-loop system dynamics is characterized by the state matrix , which is Hurwitz.
If the nonlinear term acts through a known direction , i.e., , then the admissible region of attraction shrinks to
which quantifies explicitly how the distribution of nonlinear effects among the state components affects stability margins. Matrices and are the positive define Lyapunov matrices; is the smallest eigenvalue of the matrix.
Note that increasing the feedback gain vector norm generally enlarges , which in turn increases the admissible region of attraction (45). Thus, stronger feedback improves local robustness with respect to the nonlinear perturbation.
Proof.
Let be a candidate Lyapunov function, where solves the Lyapunov equation
where .
The derivative of the Lyapunov function along the trajectories for the system (44) is obtained as follows:
Assuming the nonlinearity is locally bounded, here exist constants and such that , . Then, we obtain
Since , its spectral norm also satisfies .
Hence, for
This proves that the system is locally asymptotically stable in the region .
- Extension with directional nonlinearity.
For the considered RWP system, with , we have (for )—see Remark 5. Thus
and holds whenever
Furthermore, taking into account the condition , one can extend the above dependency:
which is consistent with the inequality (45). □
The presented stability analysis can serve as a basis for further investigations focused on robustness. Below, we provide a discussion concerning this issue with respect to the different models investigated in the paper.
Proposition 3
(Comparison of models – in terms of nonlinear distribution). Consider dynamic models – with their nonlinear term due to the presence of the function . Model exhibits the smallest admissible local region of attraction due to the strongest effective nonlinear coupling, whereas the simplified model benefits from the weakest effective nonlinear interaction in the sense of (45).
Proof.
Let the residual nonlinearities of the three RWP models – be written in the form
with a common cubic nonlinearity and model-dependent direction vectors . Under the state conventions adopted in Section 2, these vectors take the following forms:
Since
and the bound (45) is monotonically decreasing in , the corresponding Lyapunov estimates satisfy
which proves the Proposition. □
Corollary 1
(Robustness of – with regard to multiplicative uncertainty in ). Consider the three models – with state vectors , , and nominal parameter . Let the nominal linear part and input vector be denoted by and , and let the state feedback be designed for the nominal models,
with Hurwitz for each .
Suppose that the true gravitational parameter is subject to a multiplicative perturbation
and denote . Assume that the nonlinear part of the dynamics is decomposed so that the dependence on enters through the term in the second state equation, while depends only on the nominal parameter. Then the true closed-loop dynamics can be written as
where, for all three models, the perturbation has the structure
with denoting the pendulum angle and the second canonical basis vector in . In particular, for one has , and thus
Let solve the Lyapunov equation
and define . Then
Consequently, for each the equilibrium of the true closed-loop system remains locally asymptotically stable whenever
which provides explicit robustness bounds on the admissible relative uncertainty in the coefficient for the models –.
Although the robustness condition (64) has the same analytical structure for all models –, the numerical values of the Lyapunov matrices and differ significantly due to the model structure. The reduced model , having the smallest dimension and the weakest nonlinear coupling, yields the smallest norm and the largest . Consequently, the admissible uncertainty margin in is largest for , making it the most tolerant to parameter mismatch among the considered models.
4. Experimental Results
In this section, the experimental results obtained from the laboratory RWP setup can be found. Firstly, the data analysis and identification results are presented. The results are compared with the data obtained from the system manual. Then, the stabilization from control approaches is shown. One can find analysis of control systems and tuning methods, as well as performance comparisons.
The specific system parameters are presented in Table 3. Furthermore, the control signal is physically constrained: V.
Table 3.
Parameters of the RWP control system for the basic counterweight configuration [26].
The complete modeling–identification–control workflow used in this study consists of three stages, summarized in Figure 3:
- Identification stage: The parameters of the RWP are estimated using the nonlinear regression models –, based on the measured data collected from the real plant.
- Controller design stage: For a selected operating equilibrium , the chosen nonlinear model is linearized, and the stabilising controllers are synthesised using pole placement or LQR. The linearized models serve exclusively as design tools.
- Implementation stage: The resulting control law is implemented directly on the real nonlinear RWP plant. All time-domain results presented originate from experimental runs, not from simulations of the linear or nonlinear models.
4.1. Parameter Identification
Here, the results obtained for the open-loop system used in parameter identification are presented. The pendulum parameters can be adjusted by changing the position of the movable counterweight, specified by the coordinate l measured with respect to the rotation axis. Consequently, the center of mass (CoM) is shifted, affecting both the gravitational moment, and the moment of inertia , where is the mass of the adjustable counterweight. When , the downward equilibrium is stable and the inverted one unstable. Conversely, if the counterweight is moved such that , the center of mass lies above the axis and the inverted equilibrium becomes stable, while the hanging one loses stability.
In the identification experiments, a normally distributed input signal with zero mean and a standard deviation of , , was applied with a sampling time of s. The open-loop system responses were recorded, and the corresponding plots are shown in Figure 4. The parameters related to the models are summarized in Table 4.
Table 4.
Parameters estimated with LS method and depending on position of counterweight.
Figure 3.
Flowchart of the control system design procedure and its implementation on the real RWP platform.
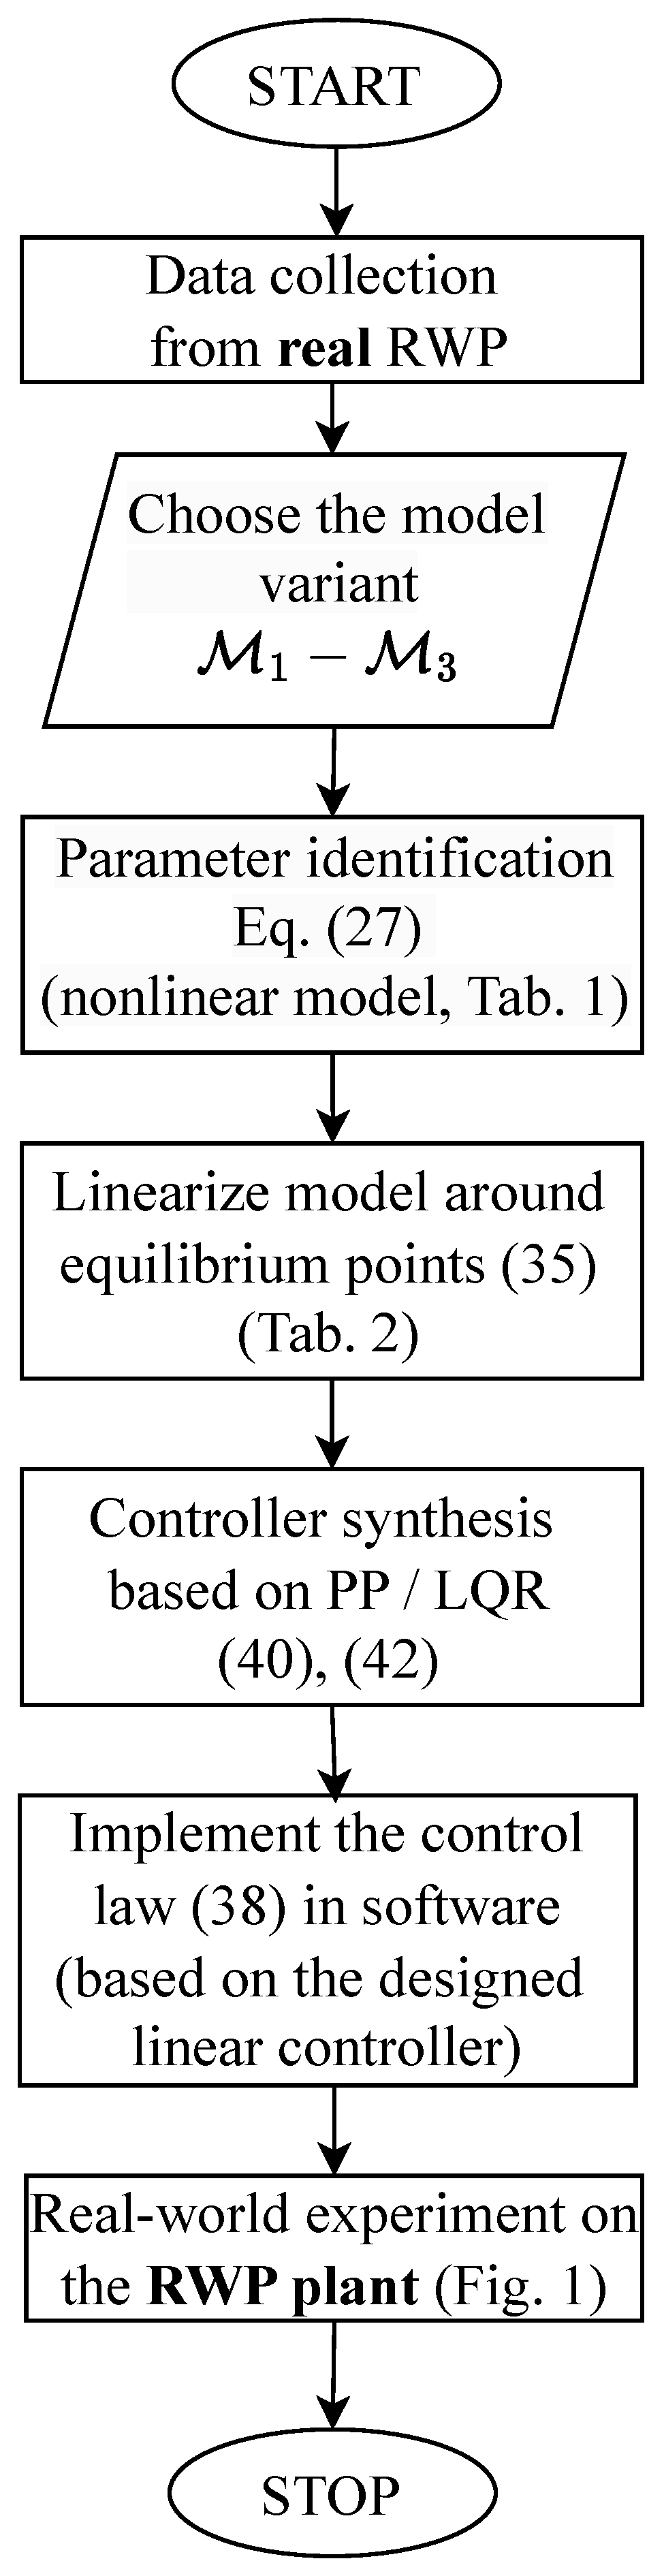
Figure 4.
View of the input and output signals used for the identification experiment.
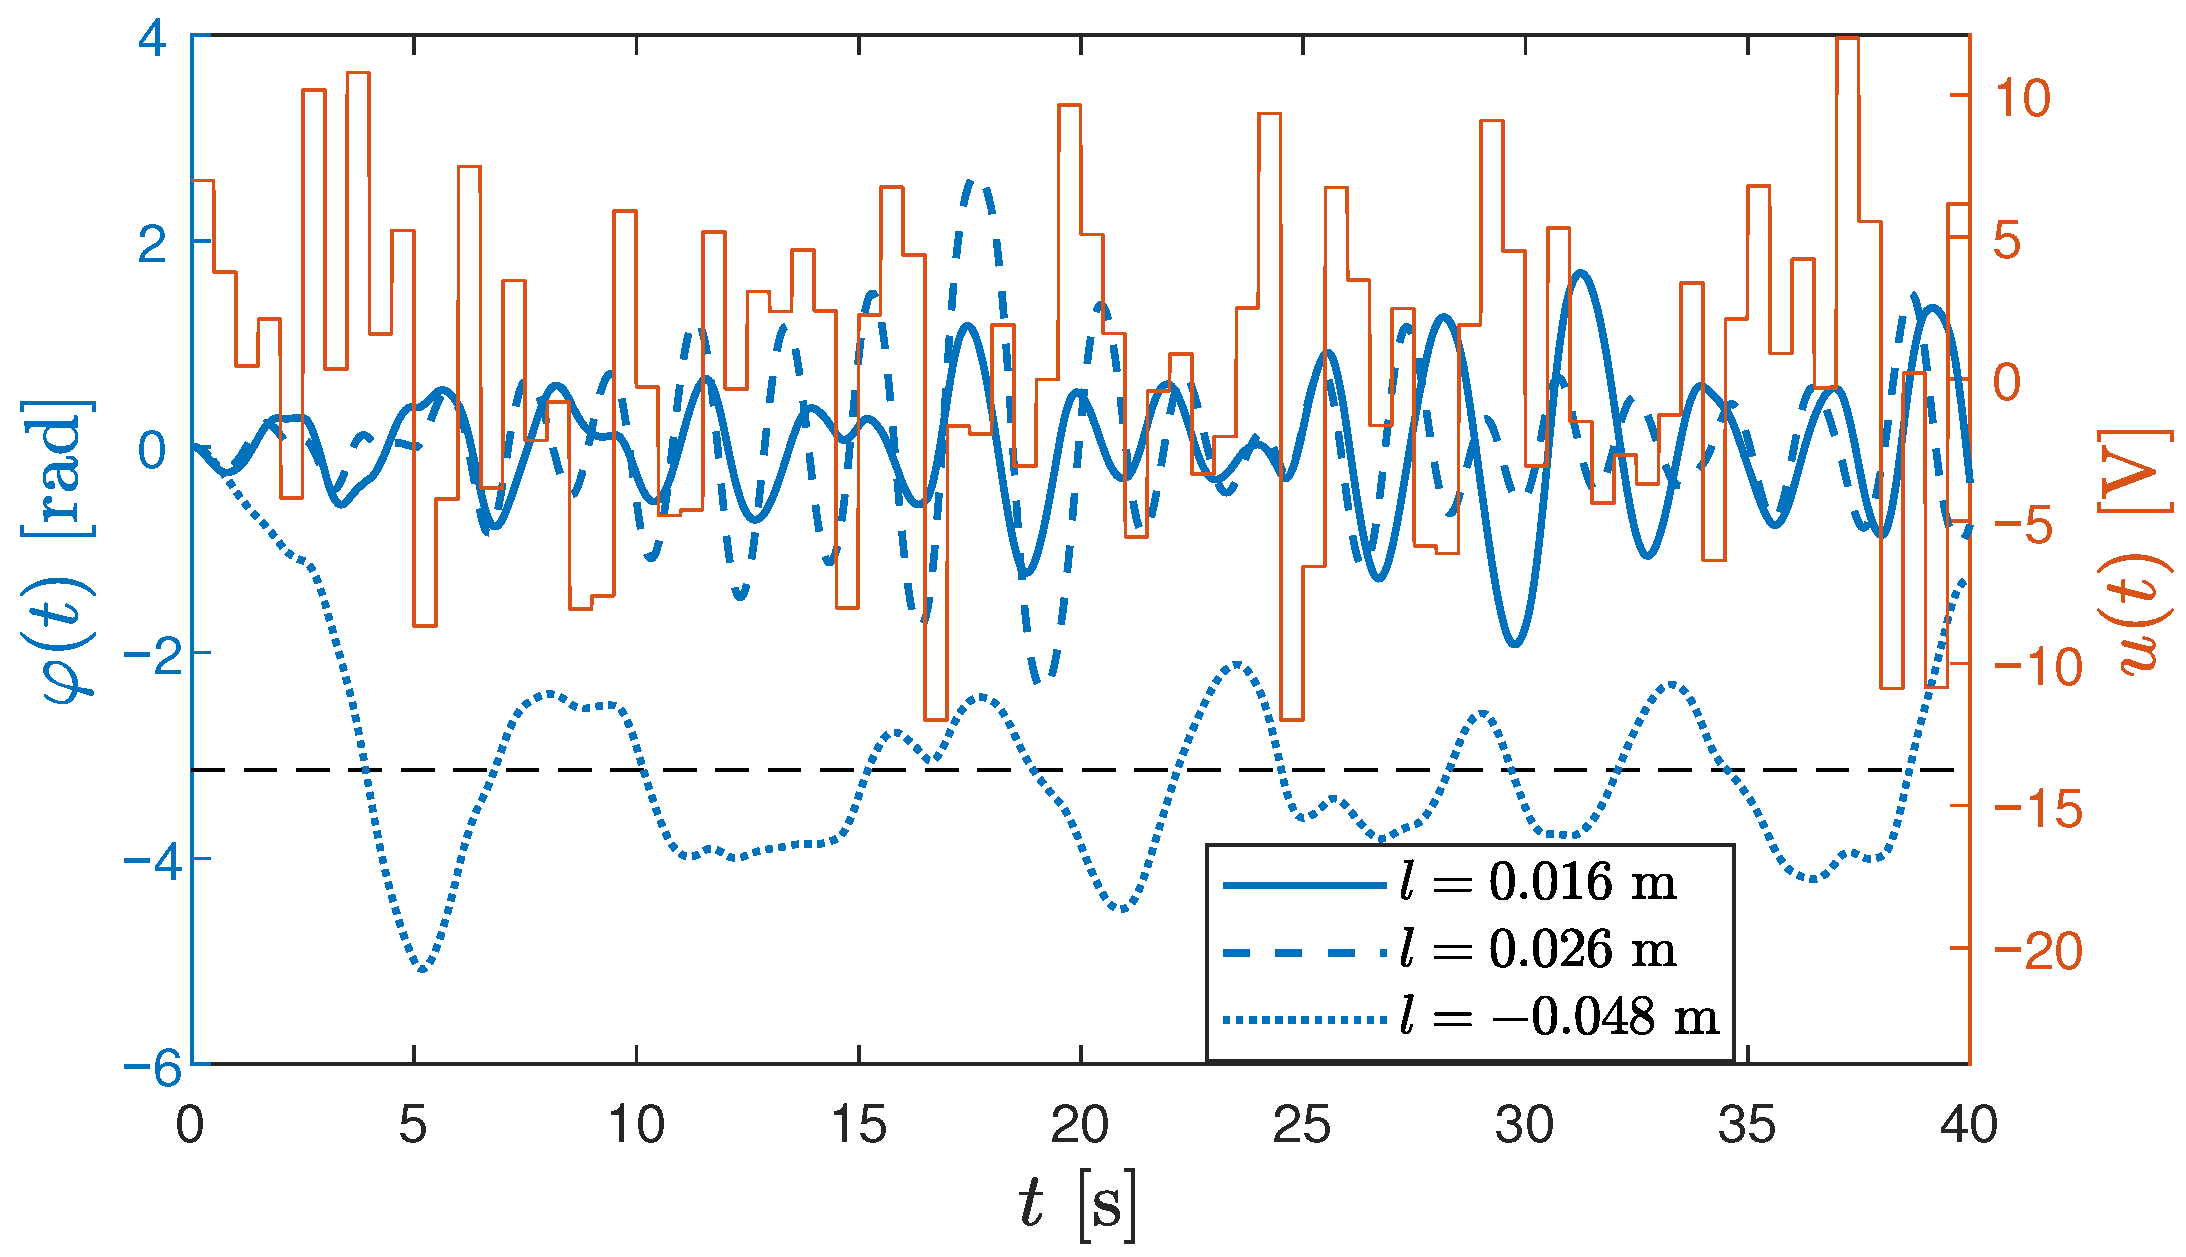
The model fit quality index was also calculated for each experiment, where the model response corresponds to the solution of the nonlinear differential equation is given as ; is the mean measurement value. Here, is the regression matrix evaluated along the model-generated trajectory. For quantitative verification, the quality indices were computed over a representative 18 s segment of the experimental data to avoid long-horizon error accumulation, a known effect in nonlinear mechanical systems [33]. The parameters exhibit a consistent trend as the system approaches its stable equilibrium. With relocation of the counterweight, models preserve dynamic structure, which makes them suitable for testing different types of control algorithms. In particular, for a change in sign is observed, resulting in a change in stability conditions between equilibrium points. For control-loop design, the models remain fully adequate, as they accurately reproduce the dominant dynamics relevant to stabilization, which is confirmed on the verification segments.
4.2. Closed-Loop System Experiments
To compare the different control approaches based on the three models investigated in this paper, swing-up–down-type experimental scenarios were considered. In order to select the equilibrium points corresponding to the lower and upper positions of the pendulum, the following rectangular reference signal was applied:
where the period is , and the reference value alternates between and . Both the downward and upright equilibrium positions were linearized separately, but due to the normalization of the angular measurement (see Remark 7), the resulting state-feedback control law has the same structure in both cases; only the sign of (Table 2) changes between the two equilibrium points.
The quantitative performance comparison includes the peak overshoot and the settling time (2% criterion), together with the integral indices. The tracking index was computed over the entire experiment duration; in contrast, the transient indices and were evaluated separately for the upward and downward equilibrium transitions:
where defines the time horizon. The quality of stabilization relative to the equilibrium point of the system output (relative to normalized angles) and the drive velocity was assessed, and the cost of control was considered.
Remark 7.
In the algorithm implementation, the measured pendulum angle is normalised such that its value is always represented within the range , namely
As a result of this normalization, the control law can be formulated consistently as a regulation problem to zero for both the upright and downward positions.
Remark 8.
To ensure stabilization of the pendulum at the upper equilibrium point, and given the local nature of the feedback and the limited control input, a swing-up energy-based algorithm was employed [34,35]. Its objective is to bring the pendulum to a position where rad. Once this condition is satisfied, the control algorithm switches, and the designed feedback takes over. However, it should be noted that the energy-based control serves only as a facilitative tool and is not the focus of the present study.
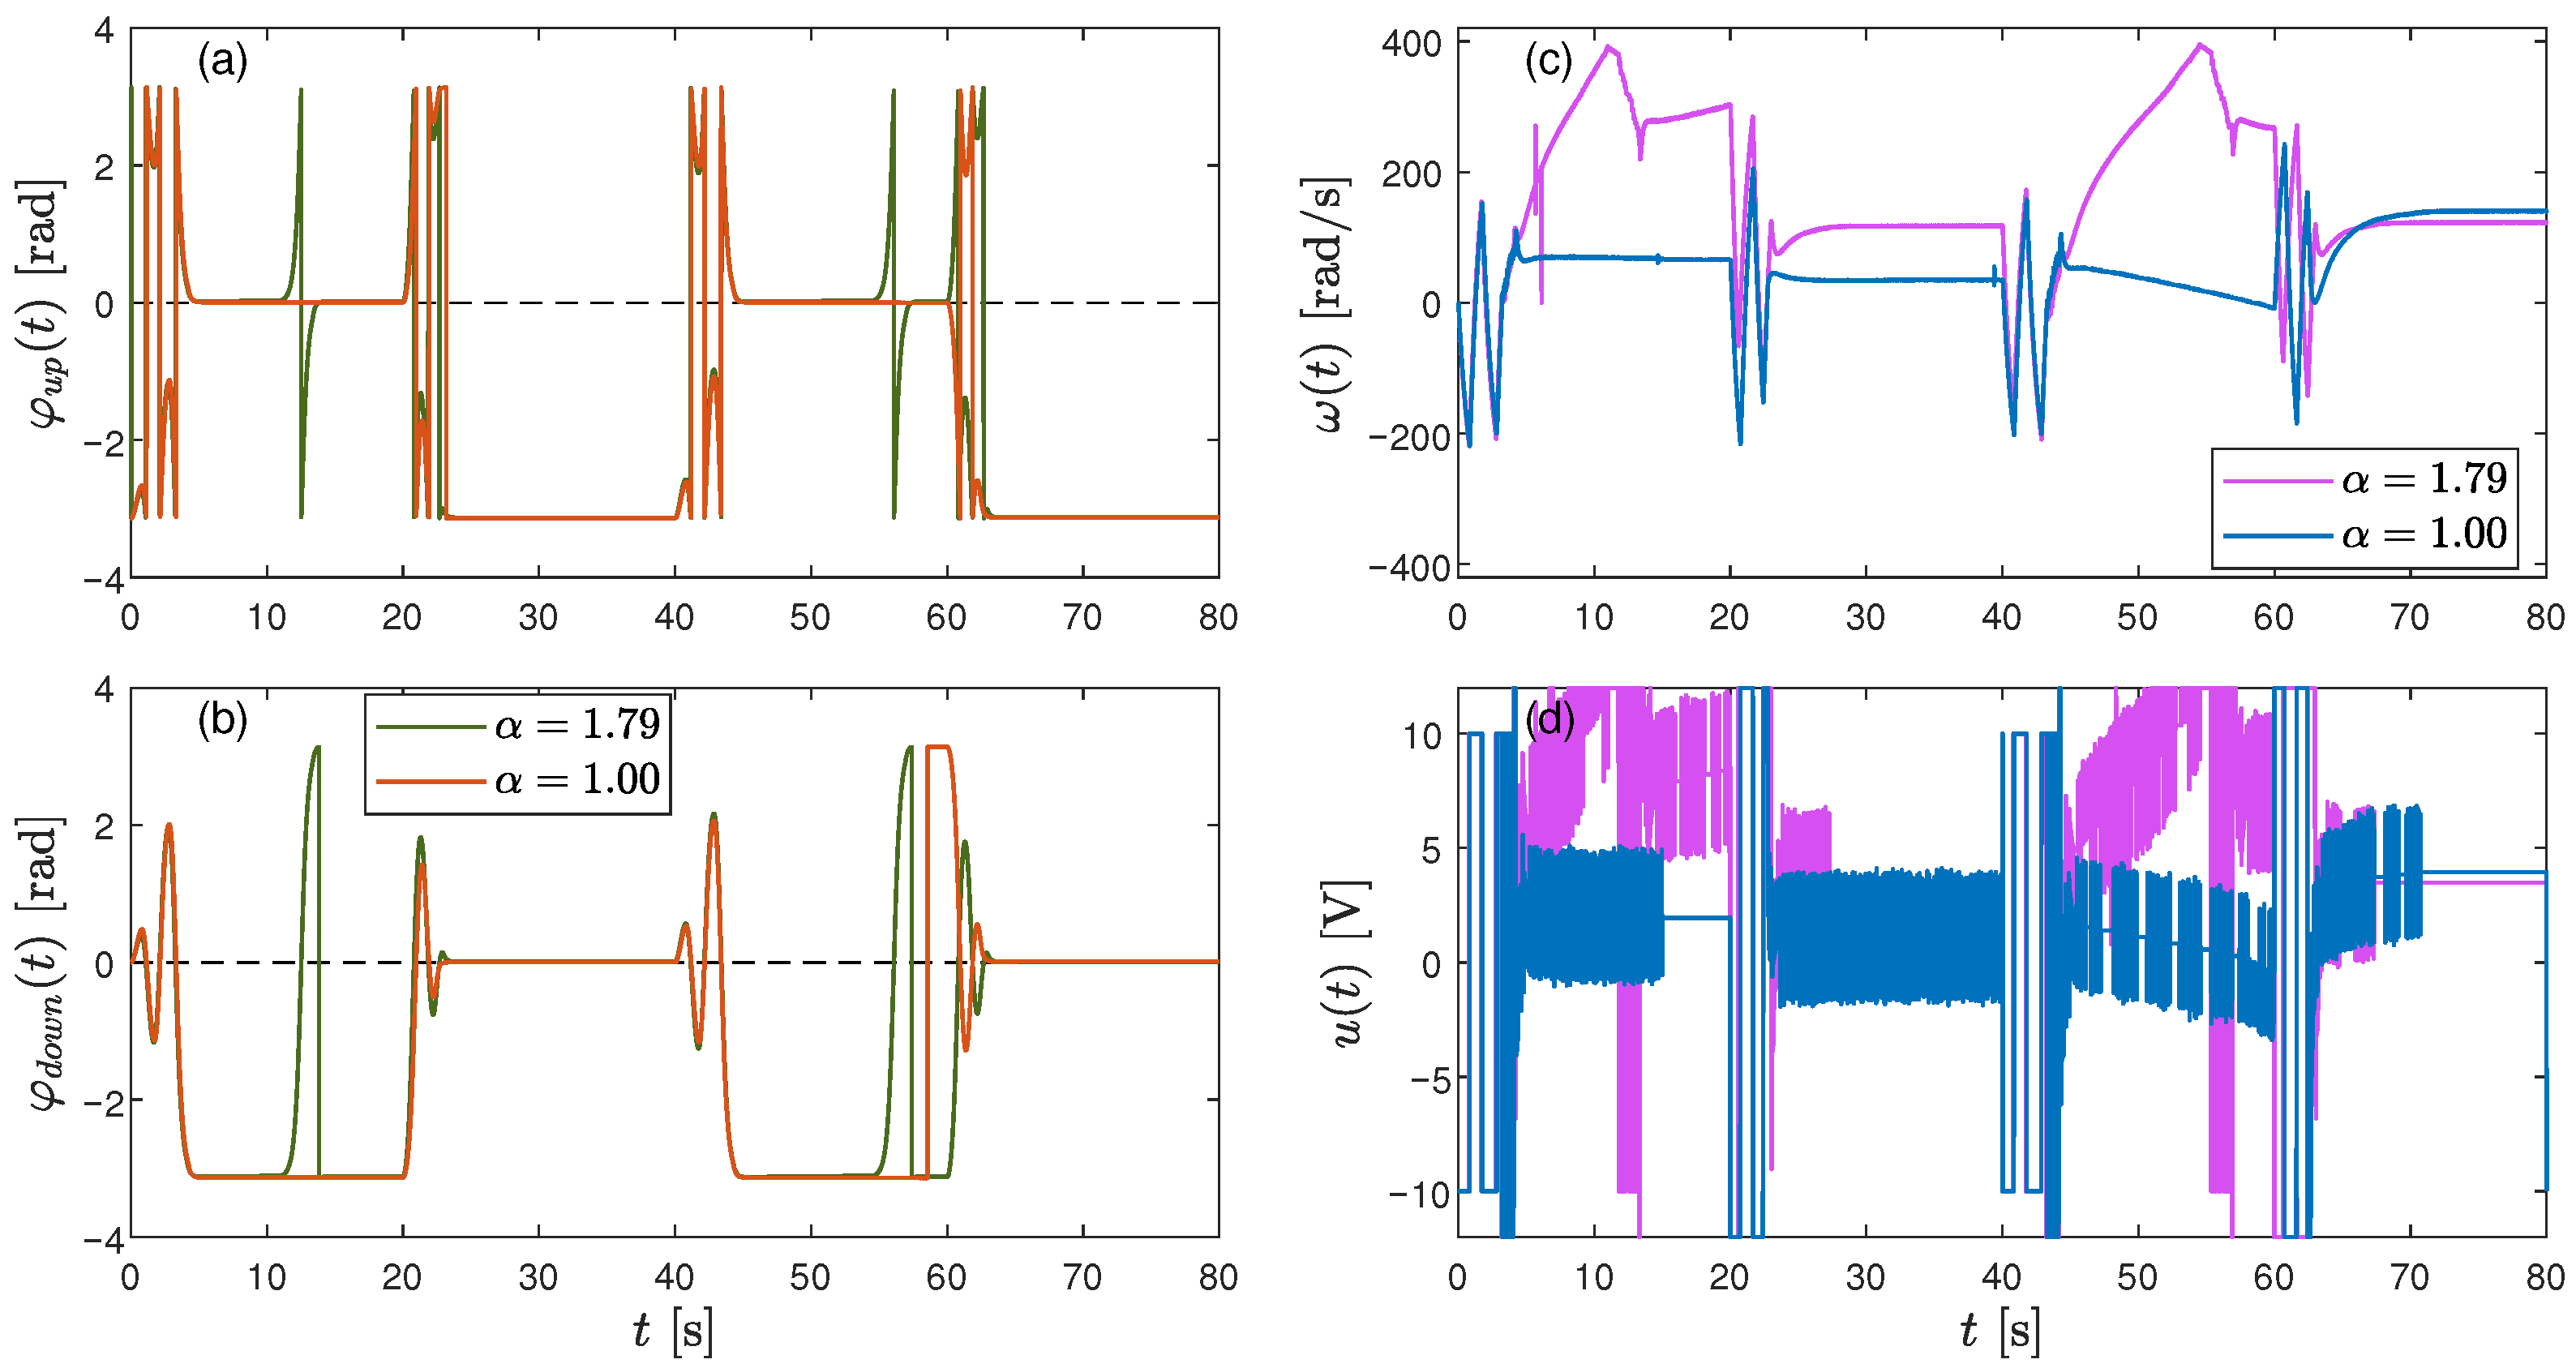
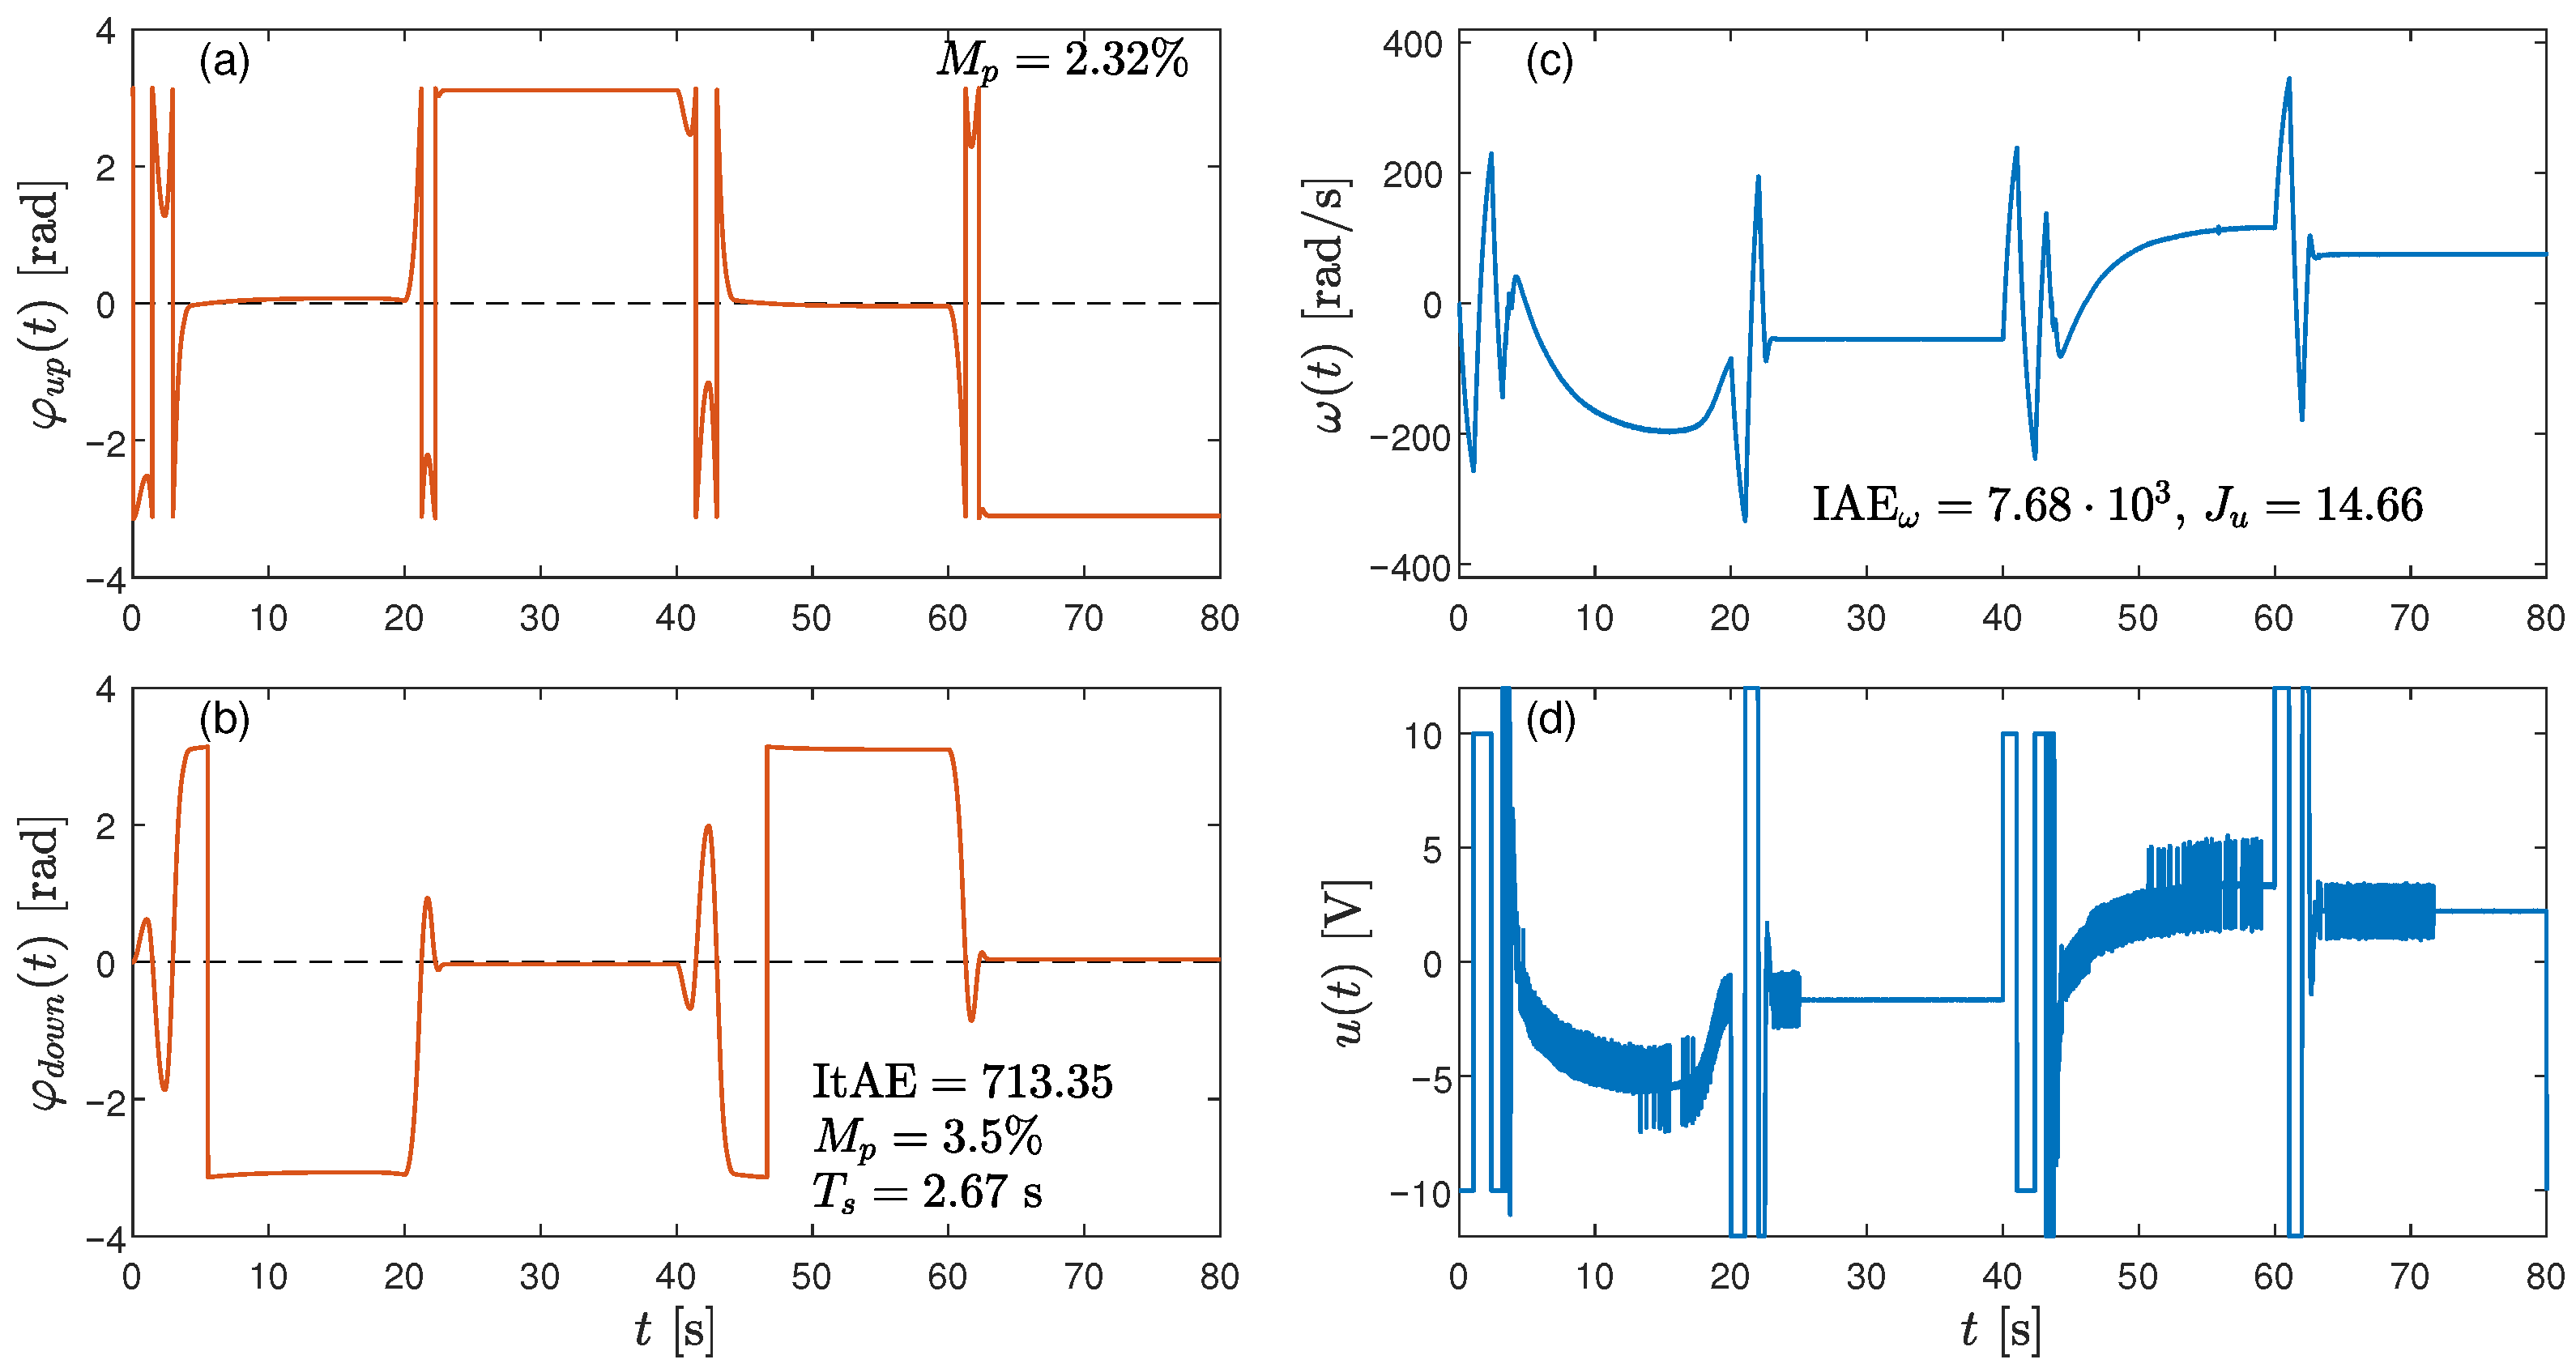
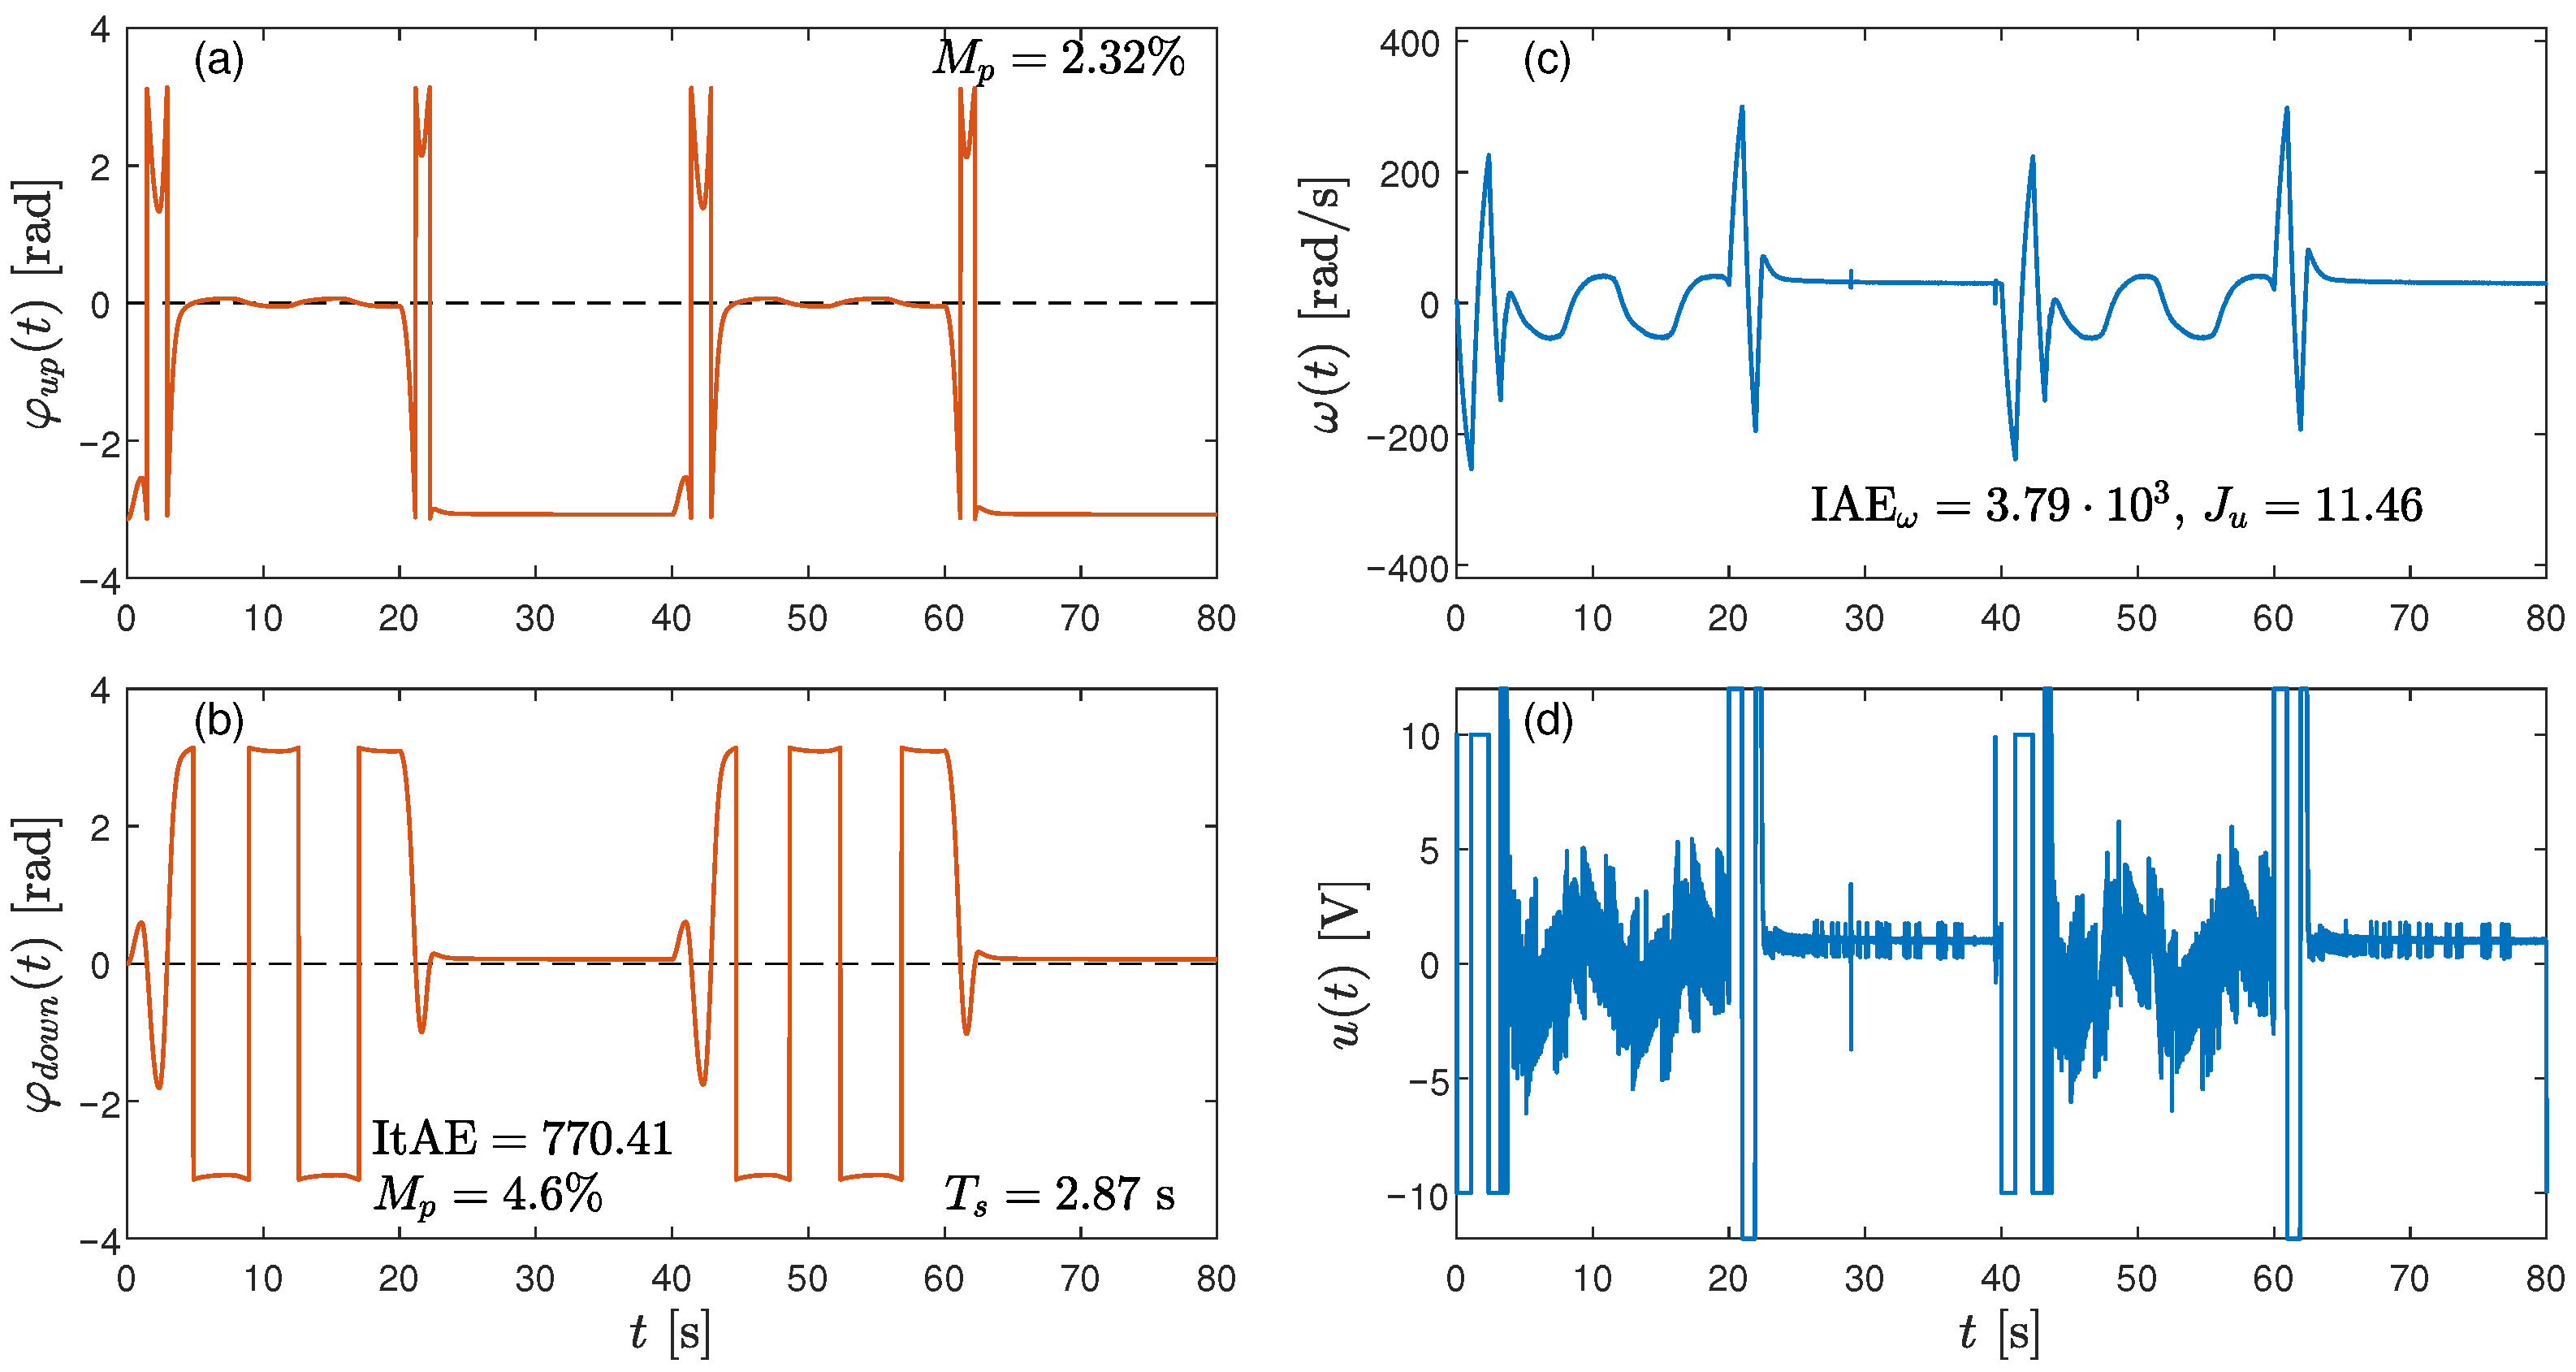
The results of the conducted experiments are illustrated by the plots shown in Figure 5, Figure 6, Figure 7, Figure 8 and Figure 9, together with the values of quality indices. When the position response failed to meet the 2% criterion, the settling time was omitted. The controller gains were selected to achieve the best possible closed-loop system performance. In addition, similar values of the settling time were maintained between experiments. On the basis of the experiments, the validity of all considered models, as well as the effectiveness of the corresponding control methods, can be confirmed.
Figure 5.
Experimental results for model, where controller parameters (250000, 1000, 0.05), ; (a) position normalized to upper point, (b) position normalized to lower point, (c) flywheel velocity, (d) control signal. The dashed line denotes the reference value. Performance indices are annotated on the figure.
Figure 6.
Experimental results for model, where controller parameters , ; (a) position normalized to upper point, (b) position normalized to lower point, (c) flywheel velocity, (d) control signal. The dashed line denotes the reference value. Performance indices are annotated on the figure.
4.2.1. Results for the Control System Designed Based on Model
Firstly, the LQR approach is applied to model . The eigenvalues of the closed-loop system state matrix, and its modulus according to LQR parameterization with , are presented in Table 5. The transfer function of the closed-loop system for the general control law (37) is given by
where is the input gain coefficient, is the vector of the transfer function numerators, is the characteristic polynomial with poles determined by the feedback gains, and is the output matrix pointing to the variables and . Note that in each considered case, the control system (with respect to the output ) retains its differentiating behavior; i.e., it differentiates the input .
Table 5.
Parameters of LQR experiments and closed-loop system eigenvalues.
The selection of the weighting coefficients in matrix is crucial for achieving the desired behavior of the real system. In particular, tuning requires an analysis of the input trajectory for the two degrees of freedom (the pendulum arm and the flywheel). Two tuning cases were considered in the experiments.
In the first case, the weight assigned to the third state variable, , was relatively small compared to the others. As shown in Figure 5, during the stabilization process—particularly around the upper equilibrium point—the angular velocity tends to increase rather than converge to zero, as would be expected under ideal conditions. In the second case, the weight associated with was increased to impose a stronger penalty on this state variable. Consequently, is limited and oscillates around zero; however, this adjustment affects the behavior of the pendulum angle, which exhibits more pronounced oscillations than in the first case, as shown in Figure 6.
Figure 7.
Experimental results for model, where controller parameters ; (a) position normalized to upper point, (b) position normalized to lower point, (c) flywheel velocity, (d) control signal. The dashed line denotes the reference value. Performance indices are annotated on the figure.
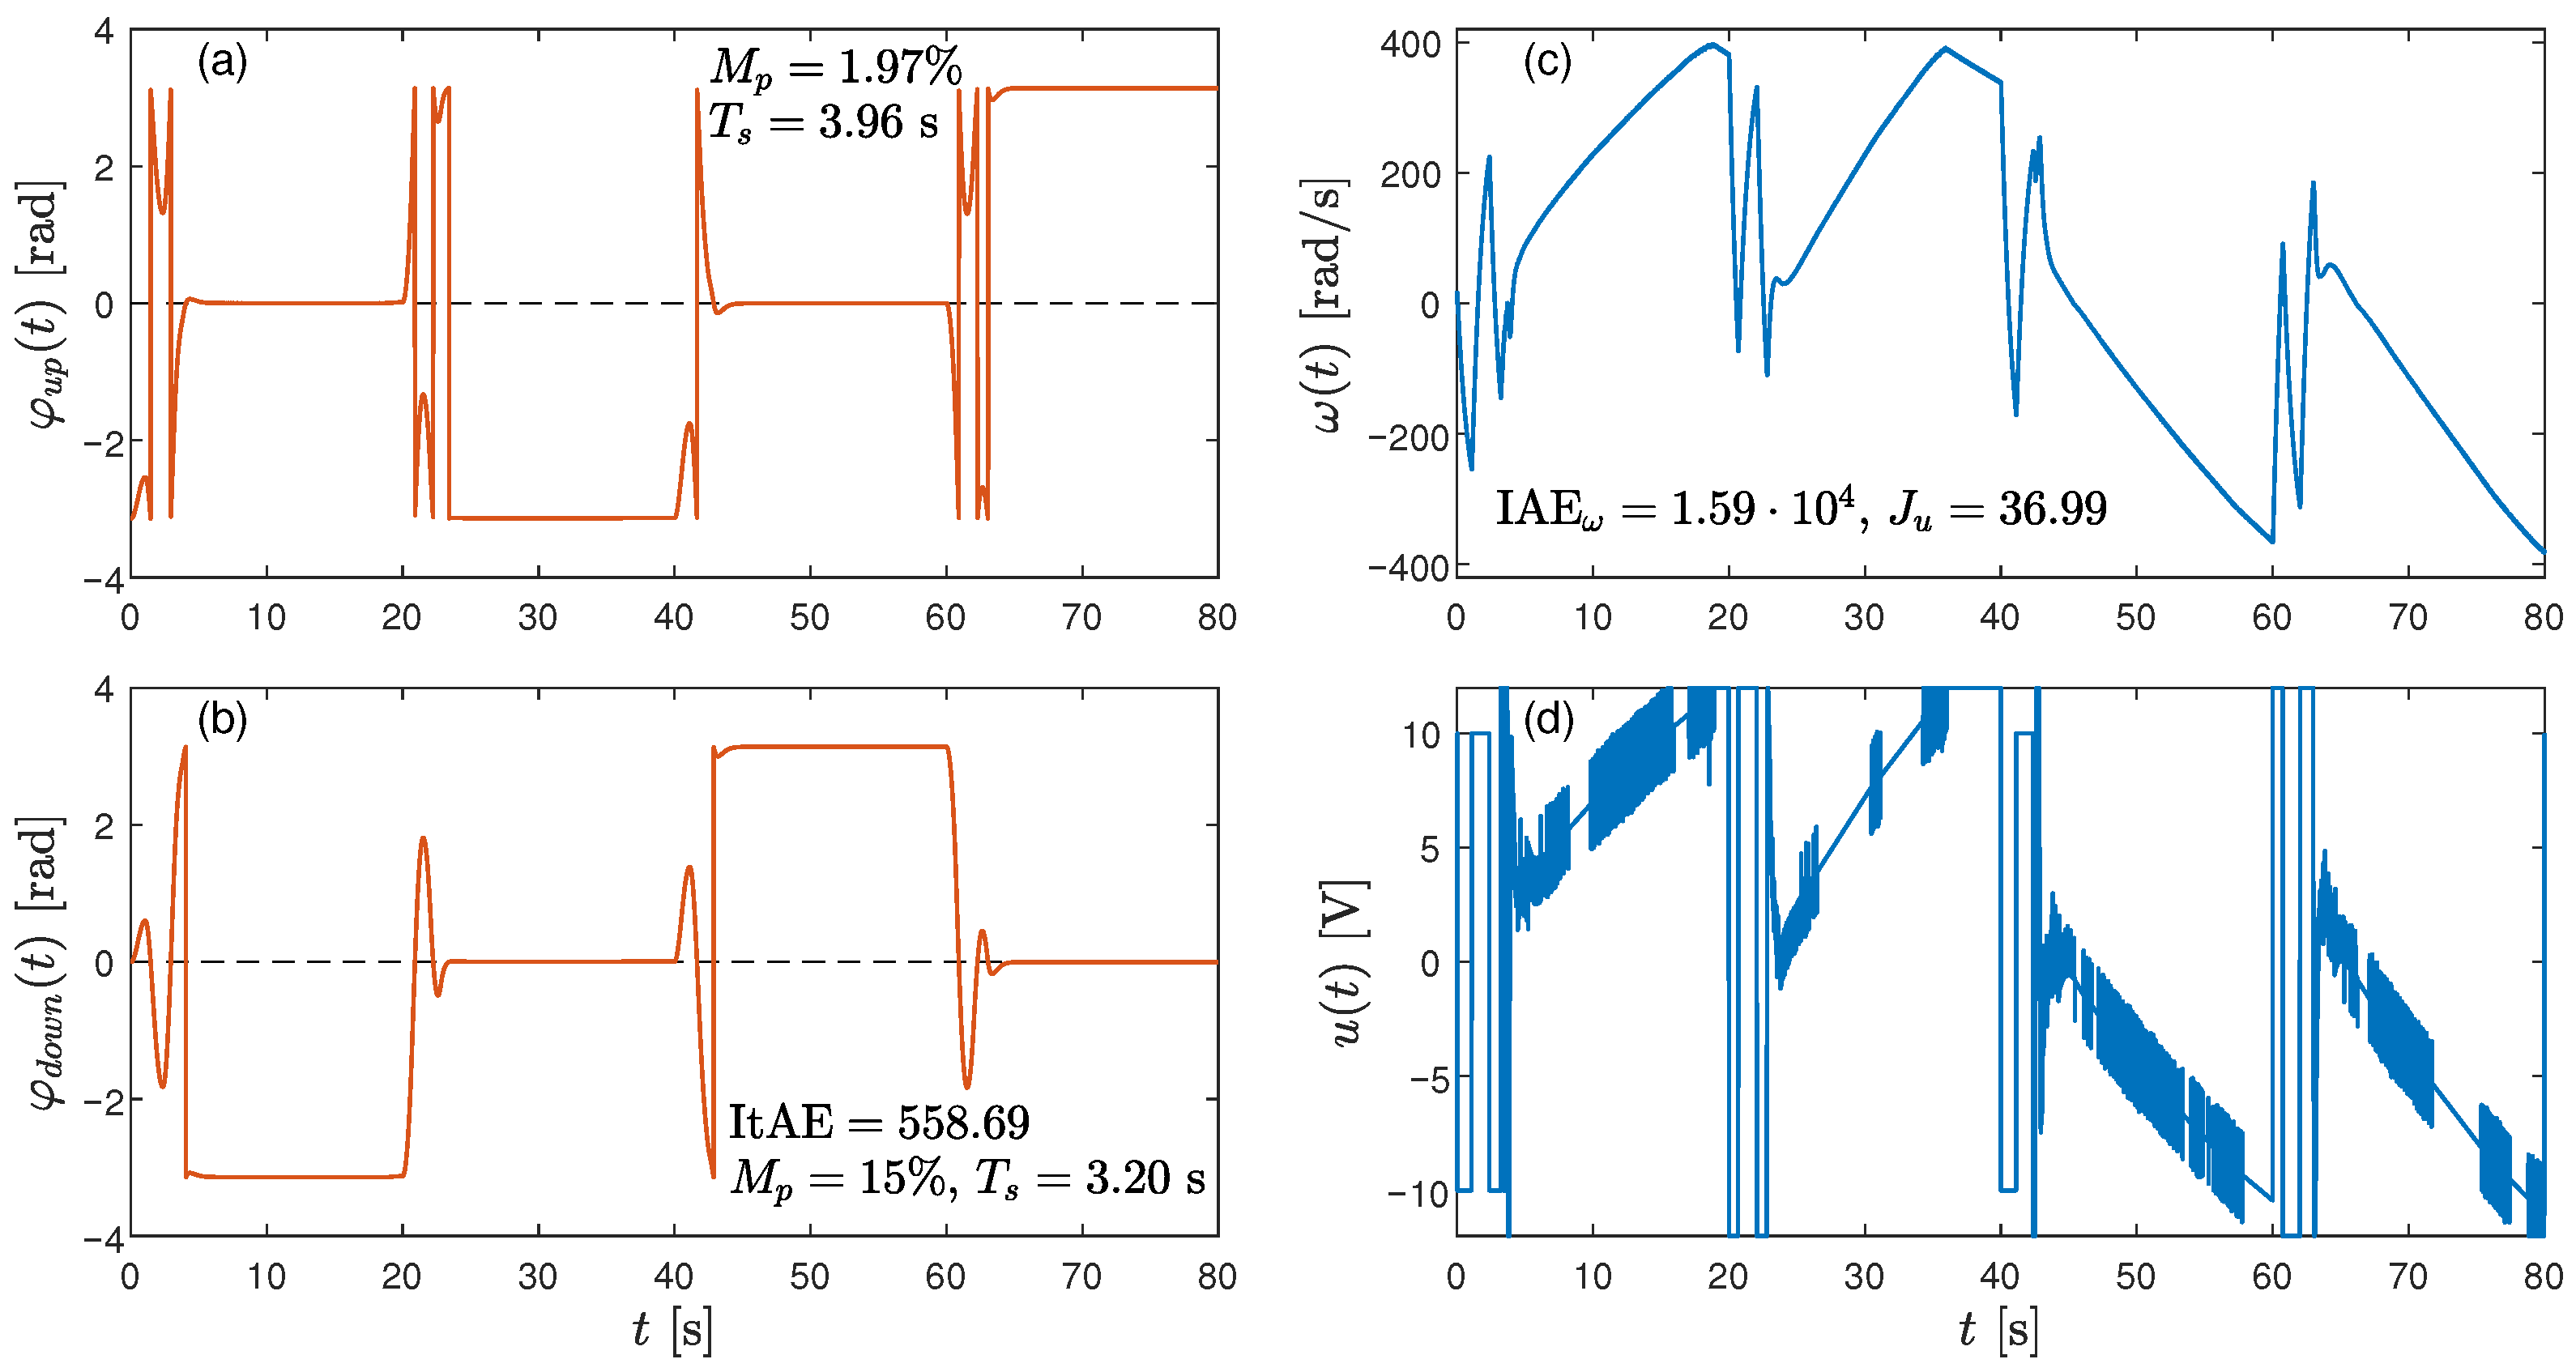
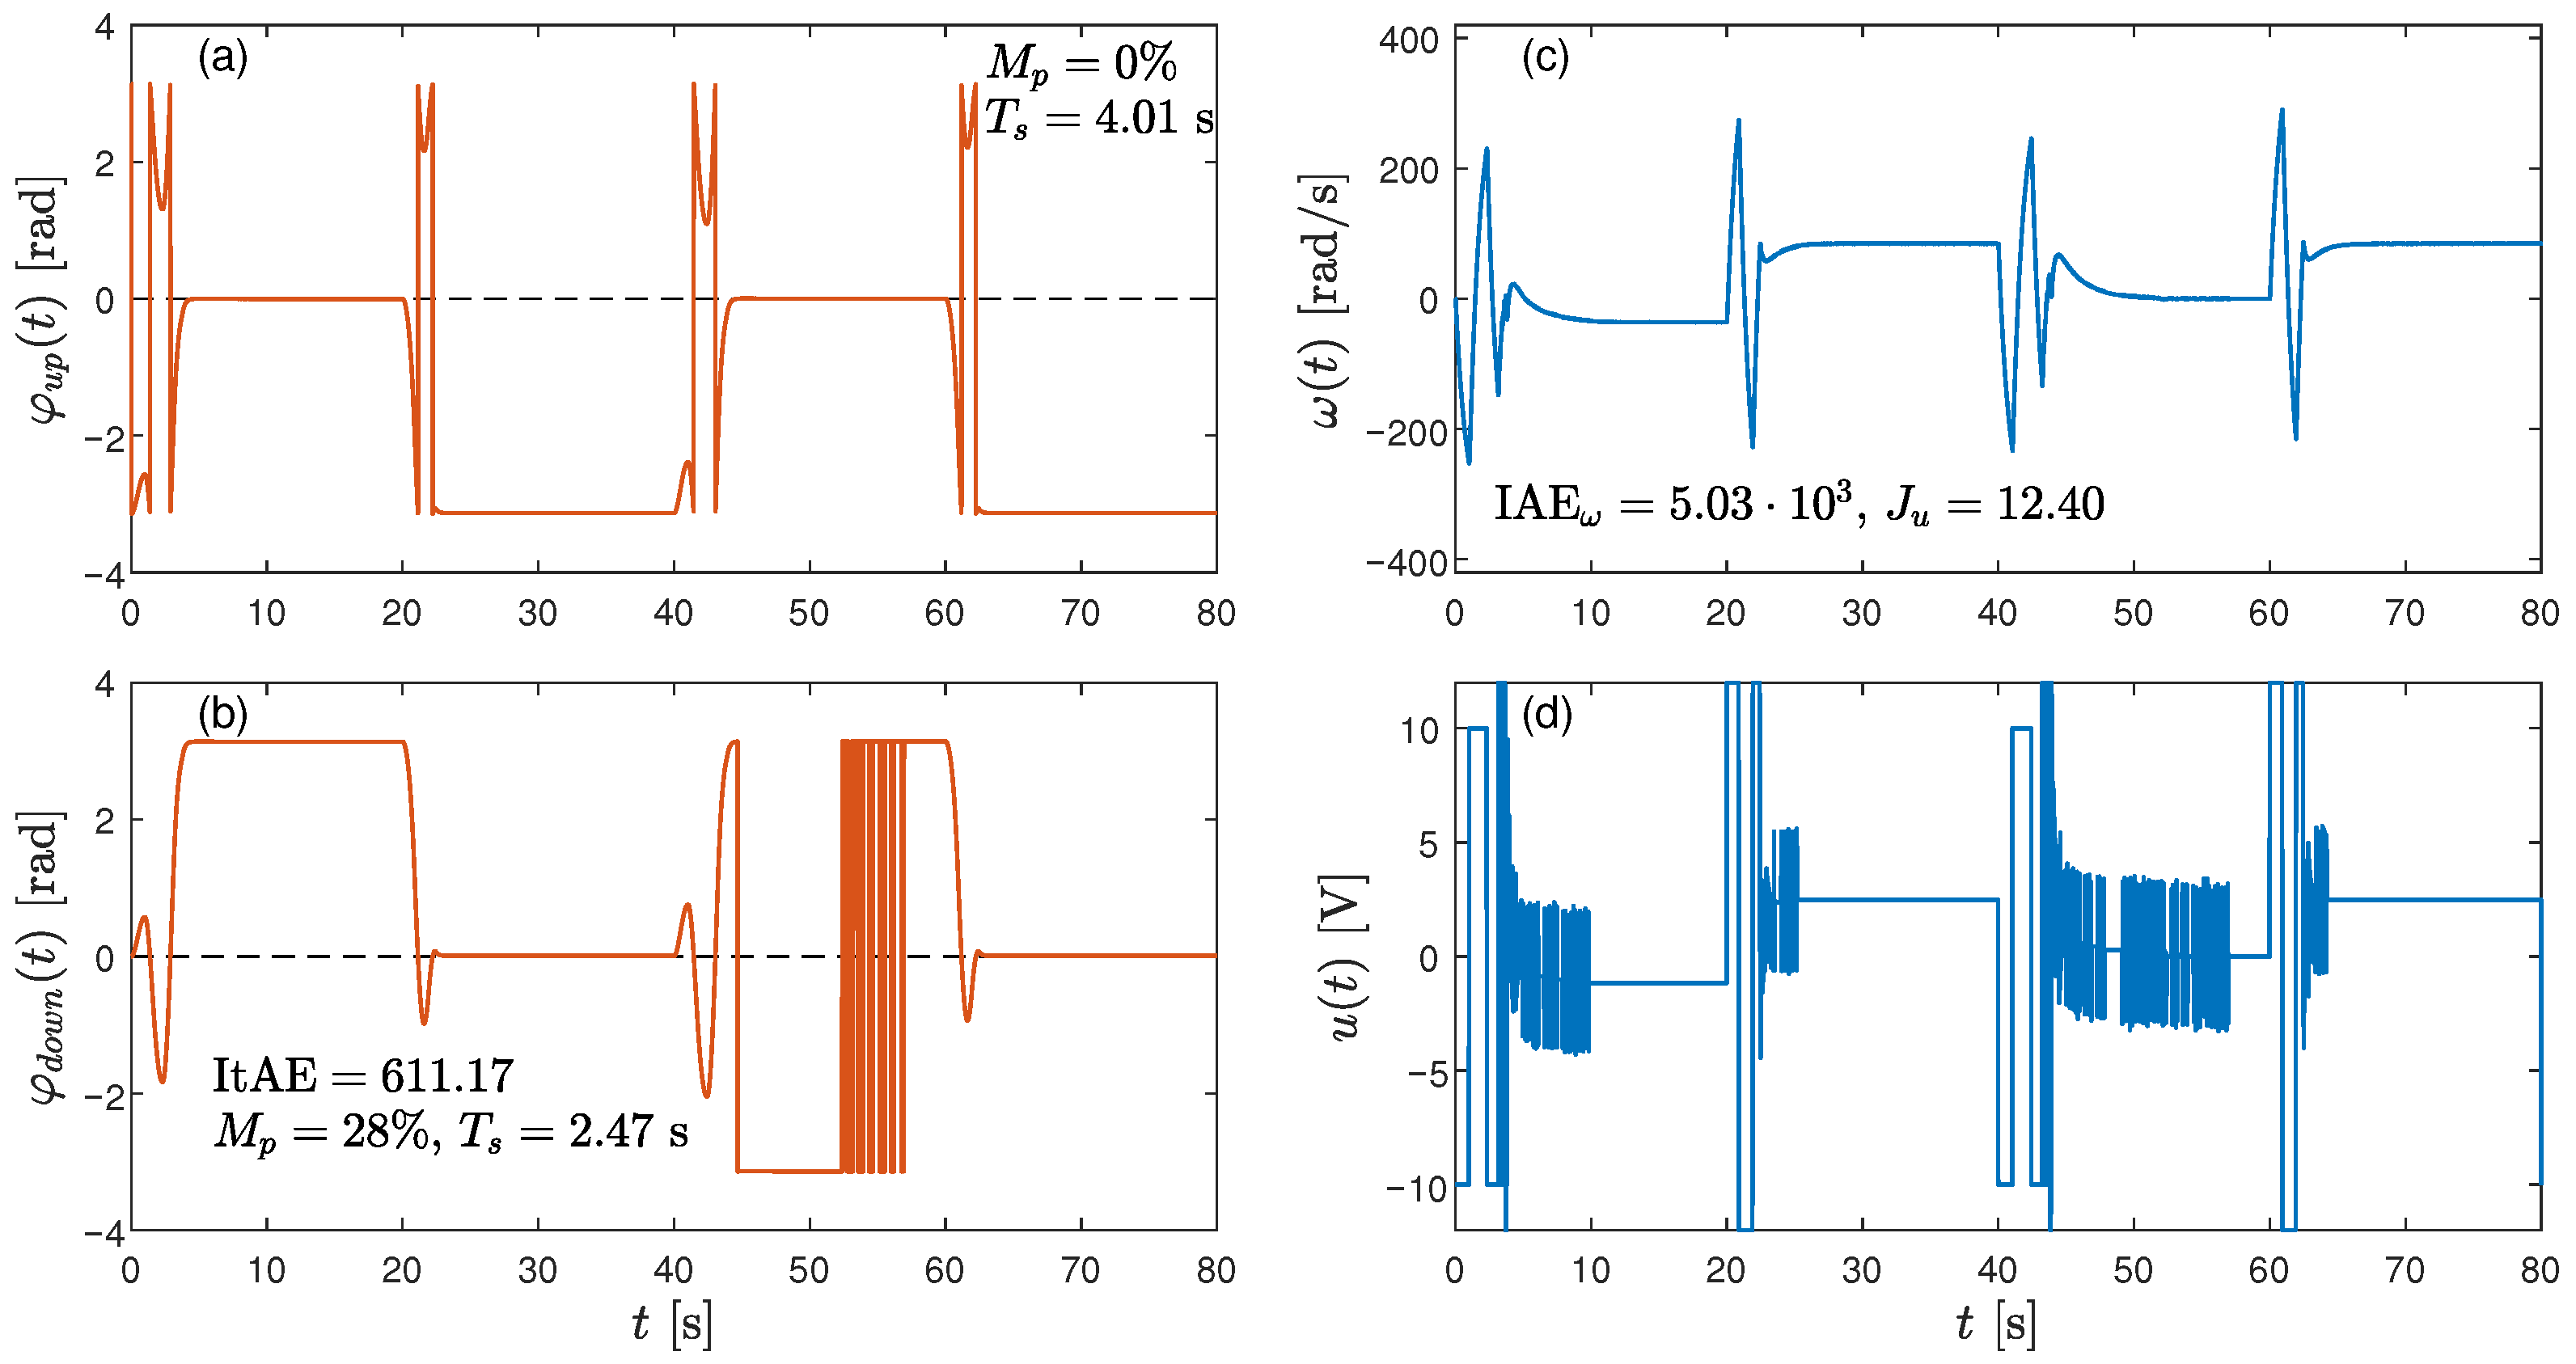
Figure 8.
Experimental results for model, where controller parameters ; (a) position normalized to upper point, (b) position normalized to lower point, (c) flywheel velocity, (d) control signal. The dashed line denotes the reference value. Performance indices are annotated on the figure.
4.2.2. Results for the Control System Designed Based on Models and
The next set of experiments (Figure 7 and Figure 8) was conducted for control systems based on models and , respectively. Due to the phase state variable configuration (with and its derivatives constituting the system state), the flywheel angular velocity is not treated as an output to be stabilized, as noted in Remark 6. As seen from the plots, precise stabilization of the pendulum arm angle at the reference value is achieved with no evident oscillations; however, this comes at the expense of an increased angular velocity , which is particularly noticeable for the third-order model . The control signal reaches values close to the saturation limits. According to the ItAE index, the model provides the best control performance. In the case of , a higher value of the parameter was chosen than for , due to the lower order of the model. In particular, for , a lower control signal energy was needed during arm stabilization. Similarly, as in Section 2.1 the controller parameters were switched depending on the current reference state. Between the upper and lower positions, gain adaptation was implemented via a gain scheduling adaptive control.
4.2.3. Experimental Evaluation of Parameter Variations
To verify the robustness of the controller to a change in the plant parameter, the counterweight of the pendulum was adjusted from the initial distance m to m, thus increasing the distance of the center of mass l and also increasing the moment of inertia . In this experimental scenario, the controller designed based on the model was employed due to its simplicity and the relatively low control energy required to stabilize the pendulum. The controller parameters remained unchanged from the previous experimental scenarios. The closed-system responses were compared for the nominal (correct) and adjusted (incorrect) system parameters (see Figure 9). Comparing the results, a noticeable increase is observed in the number of initial swings required to lift the arm. Additionally, for incorrect parameters, a shift from the equilibrium position to the upper position is observed.
Figure 9.
Experimental results for with the increased moment of inertia , where controller parameters ; (a) position normalized to upper point, (b) position normalized to lower point, (c) flywheel velocity, (d) control signal. The dashed line denotes the reference value. Model parameters for correct and incorrect configurations were used.
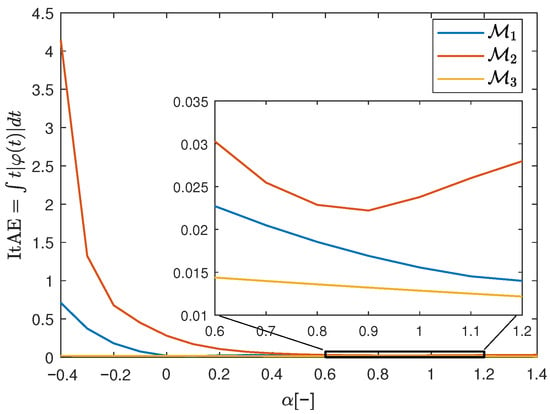
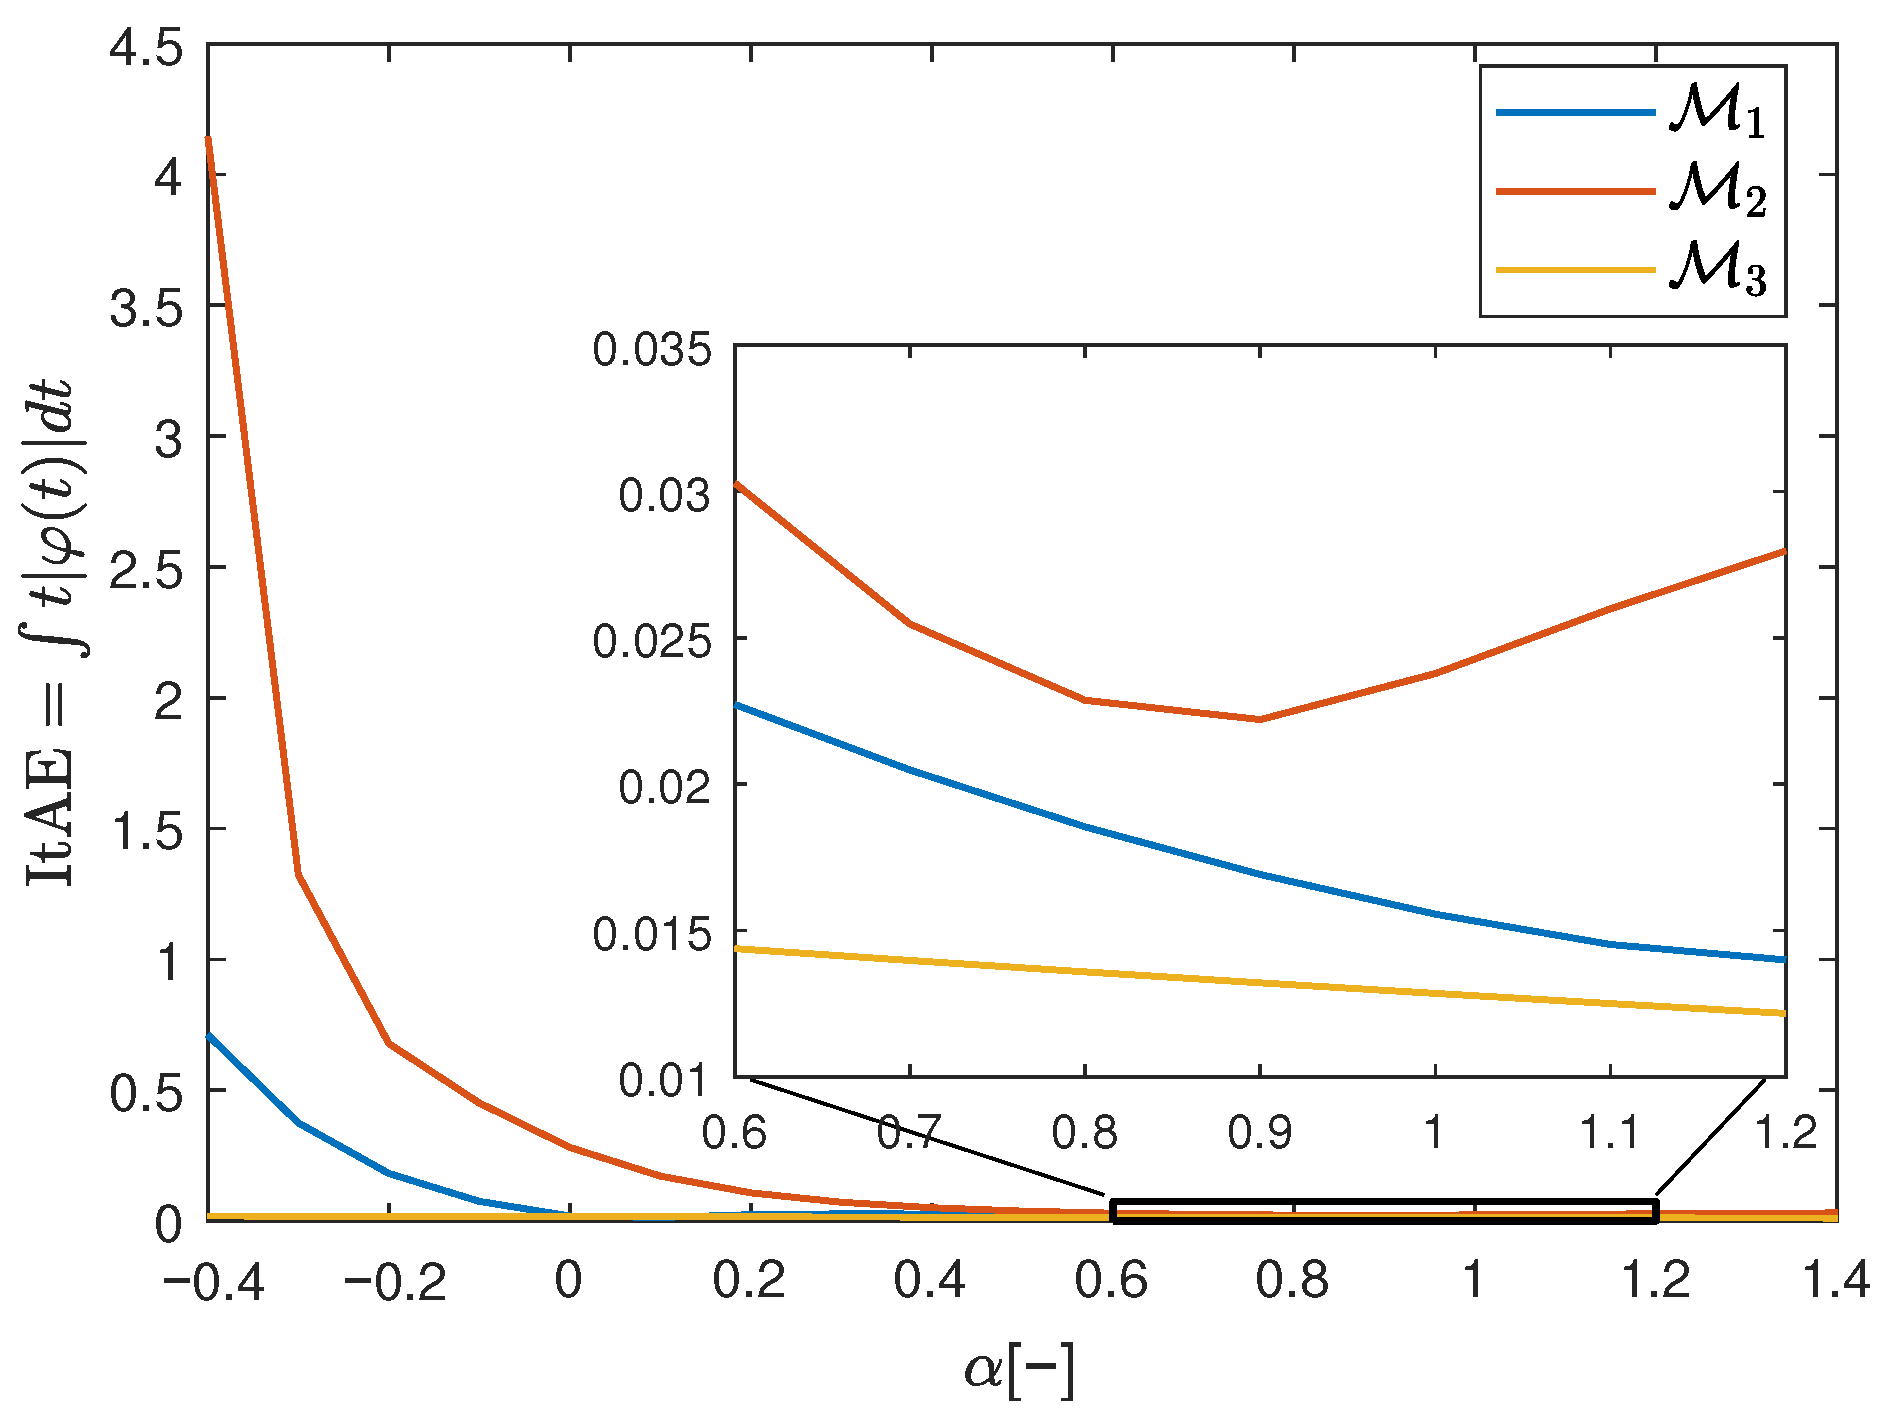
For completeness of the analysis, we also include a short parametric sensitivity study, examining how moderate uncertainty in the gravitational gain affects the closed-loop performance of the three model variants. The results, reported in Figure 10, illustrate the simulation result, how the closed-loop performance index ItAE varies with the scaling factor , showing the relative sensitivity of the three model structures. In each simulation, the system was stabilized to upper position from the initial condition over a time horizon of 3 s. The nominal parameter is used in the control synthesis, while is the real one. The analysis shows a general structural rule: model reductions that isolate the nonlinear term into lower-dimensional, weakly coupled subsystems increase stability robustness with respect to parameter variations. The result generally extends beyond the RWP case, since the robustness bound depends only on the direction and magnitude of the nonlinear term in state space, not on the specific mechanics of the pendulum. The conclusions are consistent with the presented analysis demonstrated using the Lyapunov method (64).
Figure 10.
The value of the quality index depending on the parameter inaccuracy .
5. Discussion and Conclusions
In this work, various approaches to modeling the reaction wheel pendulum control system were presented and compared. The study includes a model formulation with two output signals, as well as input–output descriptions in both full- and reduced-order variants, which also take into account dissipative effects and actuator characteristics. The linearizability conditions of each model were examined as part of the investigation of the fundamental properties of nonlinear systems. A generalized form of nonlinear model for a wider class of systems was proposed and then applied to the RWP plant. The methodology for estimating the nonlinear system parameters is described, proposing the regression for the considered models, enabling globally valid parameters. The behavior of the system and the influence on its parameters and control quality were examined with the changes in the system parameters resulting from the modification of the moment of inertia. Although the study is motivated by the RWP setup, the derived Lyapunov bounds depend only on the nonlinear-term direction and the nominal closed-loop dynamics. Therefore, the conclusions extend naturally to other underactuated or weakly nonlinear systems with similar structural properties. The parameter-dependent stability radius gives a direct guideline for selecting model complexity in feedback design when the physical parameters are uncertain or slowly varying. The comparison reveals a universal robustness–fidelity trade-off: higher-order models improve accuracy but reduce stability margins, whereas reduced models enhance robustness at the cost of dynamic detail.
As part of future research, it is planned to further develop the modeling of the RWP system, for example, by comparing various parameter identification methods. An interesting research problem also appears to be the identification of the model for different positions of the adjustable counterweight or the consideration of different disturbance signals. We also plan to consider a particular case in which the RWP system is balanced at every point and is not affected by the gravitational torque. The authors plan to extend the analysis to additional control methods, including Active Disturbance Rejection Control and feedback linearization, to investigate the sensitivity of the closed-loop systems to friction and other disturbances. Anti-windup enhanced integral action controllers, leveraging static or dynamic anti-windup schemes, can be also considered in the future.
Author Contributions
Conceptualization, J.M. and M.M.; methodology, J.M. and D.P.; software, J.M., T.T. and J.W.; validation, J.M., T.T. and J.W.; formal analysis, J.M., M.M. and D.P.; investigation, J.M., M.M. and D.P.; resources, T.T., J.W. and M.M.; data curation, M.M.; writing—original draft preparation, J.M., M.M., T.T., J.W. and D.P.; writing—review and editing, J.M. and D.P.; visualization, J.M.; supervision, D.P. and M.M.; project administration, J.M.; funding acquisition, J.M. All authors have read and agreed to the published version of the manuscript.
Funding
This research was financially supported as a statutory works of Poznan University of Technology (No. 0214/SBAD/0253 and 0211/SBAD/0125).
Data Availability Statement
The data supporting the findings of this study are included within the article. Further inquiries can be directed to the corresponding author.
Acknowledgments
The authors would like to express their gratitude to Joanna Zietkiewicz for her valuable consultations regarding the FBL method. We also wish to thank Pawel Drapikowski for making it possible to acquire the RWP system used in the present research.
Conflicts of Interest
The authors declare no conflicts of interest. The funders had no role in the design of the study, in the collection, analyses, or interpretation of data, in the writing of the manuscript or in the decision to publish the results.
Abbreviations
The following abbreviations are used in this manuscript:
| ARE | Algebraic Riccati Equation |
| CCF | Canonical Controllable Form |
| CoM | Center of Mass |
| DC | Direct Current |
| DoF | Degree of Freedom |
| FBL | Feedback Linearization |
| IWP | Inertia Wheel Pendulum |
| LTI | Linear Time-Invariant |
| LQR | Linear Quadratic Regulator |
| LS | Least Squares |
| PP | Pole Placement |
| RWP | Reaction Wheel Pendulum |
| SISO | Single Input Single Output |
| SIMO | Single Input Multiple Output |
| SVF | State Variable Filter |
| TF | Transfer Function |
Appendix A
Let us formally discuss the controllability conditions of the full model (3) and reduced model , making explicit use of the Kalman conditions. Similarly to (4), we define the following representation for the full and reduced systems, respectively:
and
We select the point at which the local controllability of both systems is investigated. As a result, we take into account the following linear approximation:
and
where . Equivalently, using (9), it can be shown that
Considering the controllability matrices and , and computing their determinants, we obtain
where
As a result, the controllability of the pair is necessary to ensure that the pair is also controllable. Since satisfies (A5), Equation (A7) can be used to express (13), which is interpreted as the feedback linearization condition. Moreover, taking this analysis into account for the specific RWP system with the parameters defined below the proof of Proposition 1 in Section 2.1, we find that the controllability conditions for the pairs and are equivalent, with the main limitation occurring when , which leads to the condition (14).
References
- Spong, M.W.; Corke, P.; Lozano, R. Nonlinear control of the reaction wheel pendulum. Automatica 2001, 37, 1845–1851. [Google Scholar] [CrossRef] [Scilit]
- Ho, Q.K.; Pham, C.B. Study on inertia wheel pendulum applied to self-balancing electric motorcycle. In Proceedings of the 2018 4th International Conference on Green Technology and Sustainable Development (GTSD), Ho Chi Minh City, Vietnam, 23–24 November 2018; IEEE: Piscataway, NJ, USA, 2018; pp. 687–692. [Google Scholar] [CrossRef] [Scilit]
- Acosta, J.; Lopez-Martinez, M. Constructive feedback linearization of underactuated mechanical systems with 2-DOF. In Proceedings of the 44th IEEE Conference on Decision and Control, Seville, Spain, 15 December 2005; pp. 4909–4914. [Google Scholar] [CrossRef] [Scilit]
- Srinivasan, B.; Huguenin, P.; Bonvin, D. Global stabilization of an inverted pendulum–Control strategy and experimental verification. Automatica 2009, 45, 265–269. [Google Scholar] [CrossRef] [Scilit]
- Nowicki, M.; Respondek, W. Input-output linearization and decoupling of mechanical control systems. Int. J. Robust Nonlinear Control. 2024, 34, 8644–8660. [Google Scholar] [CrossRef] [Scilit]
- Kondás, P.; Kapitány, P. Balancing control of a motorcycle. Pollack Period. 2023, 18, 167–171. [Google Scholar] [CrossRef] [Scilit]
- Chen, W.; Hu, Q. Sliding-mode-based attitude tracking control of spacecraft under reaction wheel uncertainties. IEEE/CAA J. Autom. Sin. 2022, 10, 1475–1487. [Google Scholar] [CrossRef] [Scilit]
- Posani, M.; Pontani, M.; Gasbarri, P. Nonlinear Slewing Control of a Large Flexible Spacecraft Using Reaction Wheels. Aerospace 2022, 9, 244. [Google Scholar] [CrossRef] [Scilit]
- Abdelmaksoud, S.I.; Al-Mola, M.H.A.; Mohamed, S.H. Wheels in Space: Modeling and Comparative Control Analysis of a Reaction Wheel Pendulum for Space Attitude Stability. In Proceedings of the 2025 International Telecommunications Conference (ITC-Egypt), Cairo, Egypt, 28–31 July 2025; IEEE: Piscataway, NJ, USA, 2025; pp. 649–654. [Google Scholar] [CrossRef] [Scilit]
- Melchiorre, M.; Colamartino, T.; Ferrauto, M.; Troise, M.; Salamina, L.; Mauro, S. Design of a Spherical Rover Driven by Pendulum and Control Moment Gyroscope for Planetary Exploration. Robotics 2024, 13, 87. [Google Scholar] [CrossRef] [Scilit]
- Huang, W.H.; Nguyen, P.T.T.; Nguyen, D.D.; Doan, H.P.; Chuang, M.Y.; Kuo, C.H. Stability Control and Path Tracking of a Self-Balancing Bicycle with a Reaction Wheel. IEEE/ASME Trans. Mechatronics 2025, 30, 2928–2936. [Google Scholar] [CrossRef] [Scilit]
- Wang, W.; Zhou, J.; Wen, C.; Long, J. Adaptive backstepping control of uncertain nonlinear systems with input and state quantization. IEEE Trans. Autom. Control. 2021, 67, 6754–6761. [Google Scholar] [CrossRef] [Scilit]
- Pyrkin, A.A.; Bobtsov, A.A.; Kolyubin, S.A. Stabilization of reaction wheel pendulum on movable support with on-line identification of unknown parameters. In Proceedings of the 4th International Conference on Physics and Control, Catania, Italy, 1–4 September 2009. [Google Scholar]
- Ryalat, M.; Laila, D.S. A robust IDA-PBC approach for handling uncertainties in underactuated mechanical systems. IEEE Trans. Autom. Control. 2018, 63, 3495–3502. [Google Scholar] [CrossRef] [Scilit]
- Salamat, B.; Elsbacher, G.; Tonello, A.M. Energy Shaping Control in Underactuated Robot Systems with Underactuation Degree Two. IEEE Robot. Autom. Lett. 2025, 10, 2734–2741. [Google Scholar] [CrossRef] [Scilit]
- Guerrero-Sánchez, M.E.; Hernández-González, O.; Lozano, R.; García-Beltrán, C.D.; Valencia-Palomo, G.; López-Estrada, F.R. Energy-based control and LMI-based control for a quadrotor transporting a payload. Mathematics 2019, 7, 1090. [Google Scholar] [CrossRef] [Scilit]
- Qiu, Q.; Yang, Y.; Chen, Y. Nonlinear H∞ Control Strategy for a Suspended Transport System of Dual Quadrotor UAVs. Int. J. Robust Nonlinear Control. 2025. [Google Scholar] [CrossRef] [Scilit]
- Sumioka, T.; Akimoto, K.; Tsujimura, T.; Takayanagi, S.; Fukushima, K.; Nose, T. Rider Cooperative Control of Rear-Wheel-Swing Motorcycle Based on Divergent Component of Motion. IEEE Robot. Autom. Lett. 2023, 9, 223–230. [Google Scholar] [CrossRef] [Scilit]
- Zaborniak, D.; Patan, K.; Witczak, M. Design, implementation, and control of a wheel-based inverted pendulum. Electronics 2024, 13, 514. [Google Scholar] [CrossRef] [Scilit]
- Braun, P.; Bhardwaj, A.; Brentari, M.; Zaccarian, L.; Saveriano, M. Static anti-windup with shifted equilibria applied to a Segway-like vehicle. Automatica 2024, 169, 111830. [Google Scholar] [CrossRef] [Scilit]
- Fuentes, F.; Lozano, S.; Gomez, M.; Vielma, J.C.; Lopez, A. Determining the dynamic characteristics of a multi-story RC building located in Chile: A comparison of the results between the nonparametric spectral analysis method and the parametric stochastic subspace identification method. Appl. Sci. 2022, 12, 7760. [Google Scholar] [CrossRef] [Scilit]
- Granda, M.; Fernandez, C.; Barrado, A.; Zumel, P. Nonparametric Frequency Response Identification for Dc-Dc Converters Based on Spectral Analysis with Automatic Determination of the Perturbation Amplitude. Sensors 2021, 21, 3234. [Google Scholar] [CrossRef] [Scilit]
- González, R.A.; Rojas, C.R.; Pan, S.; Welsh, J.S. Consistent identification of continuous-time systems under multisine input signal excitation. Automatica 2021, 133, 109859. [Google Scholar] [CrossRef] [Scilit]
- Liu, T.; Qin, Z.; Hong, Y.; Jiang, Z.P. Distributed optimization of nonlinear multiagent systems: A small-gain approach. IEEE Trans. Autom. Control. 2022, 67, 676–691. [Google Scholar] [CrossRef] [Scilit]
- Jin, Z. Global Asymptotic Stability Analysis for Autonomous Optimization. IEEE Trans. Autom. Control. 2025, 70, 6953–6960. [Google Scholar] [CrossRef] [Scilit]
- Rosół, M.; Piłat, A.; Tumau, A. Time-optimal control for reaction wheel pendulum. In Proceedings of the 2016 21st International Conference on Methods and Models in Automation and Robotics (MMAR), Miedzyzdroje, Poland, 29 August–1 September 2016; IEEE: Piscataway, NJ, USA, 2016; pp. 1057–1062. [Google Scholar] [CrossRef] [Scilit]
- Jakubczyk, B.; Respondek, W. On Linearization of Control Systems. Bull. L’Académie Pol. Sci. Série Sci. Math. 1980, 28, 517–522. [Google Scholar]
- Isidori, A. Nonlinear Control Systems, 3rd ed.; Springer: London, UK, 1995. [Google Scholar]
- Michalski, J.; Mrotek, M.; Retinger, M.; Kozierski, P. Adaptive Active Disturbance Rejection Control with Recursive Parameter Identification. Electronics 2024, 13, 3114. [Google Scholar] [CrossRef] [Scilit]
- Block, D.J.; Åström, K.J.; Spong, M.W. The Reaction Wheel Pendulum; Number 1; Morgan & Claypool Publishers: San Rafael, CA, USA, 2007; pp. 1–105. [Google Scholar]
- Montoya, O.D.; Gil-González, W. Nonlinear analysis and control of a reaction wheel pendulum: Lyapunov-based approach. Eng. Sci. Technol. Int. J. 2020, 23, 21–29. [Google Scholar] [CrossRef] [Scilit]
- Lai, B.; Bernstein, D.S. Generalized forgetting recursive least squares: Stability and robustness guarantees. IEEE Trans. Autom. Control. 2024, 69, 7646–7661. [Google Scholar] [CrossRef] [Scilit]
- Ribeiro, A.H.; Tiels, K.; Umenberger, J.; Schön, T.B.; Aguirre, L.A. On the smoothness of nonlinear system identification. Automatica 2020, 121, 109158. [Google Scholar] [CrossRef] [Scilit]
- Åström, K.J.; Furuta, K. Swinging up a pendulum by energy control. Automatica 2000, 36, 287–295. [Google Scholar] [CrossRef] [Scilit]
- Xin, X.; Kaneda, M. Analysis of the energy-based control for swinging up two pendulums. IEEE Trans. Autom. Control. 2005, 50, 679–684. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).