


Abstract
To address the safety and efficiency challenges in planning emergency evacuation routes for personnel in complex environments, this study proposes an integrated and improved ant colony optimization (ACO) with a genetic algorithm (GA). First, an emergency evacuation route planning model for subway incidents is constructed by optimizing evacuation time, route risk, and the passenger panic index. Then, the ant colony algorithm is enhanced by assigning pheromones to each objective and optimizing the state transition probabilities, which helps avoid premature convergence on local optima. Simultaneously, a GA is employed to conduct a global search and generate an initial population, which serves as the initial pheromone for the ACO. This approach achieves the integration of ACO and GA, enabling them to synergistically leverage the advantages of global and local search. Finally, an evacuation simulation was conducted using a specific subway station as an example, and the results were compared with those of traditional algorithms. The results indicate that the proposed algorithm can find the optimal solution for all evacuation routes and significantly improve convergence speed and global search capabilities. In simulations across different hazard development stages, the proposed integrated method outperforms basic ACO and SSA by accounting for evacuation time, safety, and crowd panic to yield optimal routes.
1. Introduction
Accelerating urbanization and rising population densities have made underground railway systems a pivotal part of urban transit, greatly facilitating daily commutes. However, their inherently enclosed infrastructure and the high concentration of passengers within them give rise to underlying public safety concerns that cannot be overlooked. The complex internal layout of underground stations, combined with an enclosed environment, limited exits, and high passenger flow, can lead to severe casualties and property damage in emergencies, presenting a serious challenge. Therefore, research on metro emergency evacuation route planning is crucial. Its value lies both in modeling complex crowd dynamics and in yielding practical benefits such as enhanced evacuation efficiency, reduced casualties, and minimized property damage during crises. Ultimately, this work is fundamental to improving urban safety and resilience, making it a vital field of study in contemporary emergency management.
In current research, path planning primarily encompasses global path planning [1] and local path planning [2]. Global path planning entails finding a safe and optimal route from start to destination on a known map, subject to given optimization objectives. Local path planning relies on real-time environmental sensing to detect nearby obstacles, enabling the algorithm to determine the optimal route from the current node to the target. Common global path-planning algorithms include the Dijkstra algorithm [3], A*algorithm [4], etc.; local path-planning algorithms primarily include the Artificial Potential Field [5]. While various path-planning algorithms each exhibit distinct advantages in specific applications, they are invariably accompanied by inherent limitations. For instance, global planning algorithms excel at finding optimal paths by analyzing the entire known environment, but this comes at the cost of high computational overhead, making them impractically slow for large or complex maps. Conversely, local planning algorithms demonstrate remarkable agility and robustness in real-time obstacle avoidance by reacting to immediate sensory data. Nevertheless, their myopic nature, which focuses only on the proximate surroundings, makes them susceptible to becoming trapped in local optima [6]. With ongoing research by scholars both domestically and internationally, intelligent optimization algorithms have also been widely applied in path planning, such as genetic algorithms (GAs), ant colony optimization (ACO), and particle swarm optimization (PSO) [7], etc., with enhancements made to intelligent optimization algorithms to derive superior paths.
Ant colony optimization is a heuristic algorithm that simulates the foraging behavior of ants, characterized by its robustness and strong adaptability [8]. Wang et al. [9] incorporated the advantages of quantum bit concepts into the ant colony optimization, designing an adaptive quantum ant colony optimization to solve multi-objective optimization models for emergency evacuation routes. Mohamed et al. [10] enhanced the ant colony optimization algorithm for planning tourist routes in hilly terrain by refining its pheromone update mechanism and initialization parameters, thus overcoming key limitations of traditional methods. Katada et al. [11] developed an enhanced ant colony optimization method for planning UAV flight paths capable of avoiding no-fly zones and navigating obstacles, validating its effectiveness through both simulations and real-world flight tests. Yamamoto et al. [12] quantitatively evaluated evacuation route safety by integrating ant colony optimization with hierarchical clustering of roads based on congestion probability and facilitated multi-path comparison via GIS visualization. Charis et al. [13] extended the ant colony optimization algorithm by integrating fuzzy inference systems with the RMSE criterion to address multi-objective path planning for unmanned surface vehicles. Liu et al. [14] optimized the ant colony optimization by introducing six strategies: incorporating an obstacle influence factor, imposing dynamic constraints on pheromones, proposing a novel backtracking mechanism, enhancing heuristic information, refining the evaporation factor pheromone formula, and implementing an improved elite ant retention strategy. These enhancements significantly improved the efficiency of path planning. Aziz et al. [15] applied the ant colony optimization algorithm to plan evacuation routes for volcanic eruptions, based on five aggregated parameters: distance, speed, barriers, density, and safety points. Bassolillo et al. [16] proposed a method for optimizing drone delivery routes in smart cities by integrating the ant colony optimization algorithm with model predictive control, enabling efficient destination allocation and dynamic obstacle avoidance. However, ant colony optimizations have two key limitations in dynamic scenarios: a tendency to converge on local optima, which hinders rapid adaptation to change, and an inability to effectively balance multiple objectives due to their reliance on a single pheromone-heuristic mechanism.
A genetic algorithm is an evolutionary algorithm that simulates the process of biological evolution. They operate by maintaining a population of candidate solutions and iteratively applying genetic operators—namely, selection, crossover, and mutation. This cyclical process continuously produces new populations. This algorithm is widely applied in fields such as forecasting [17] and path planning. For path planning in hazardous dynamic environments, Lee [18] proposed a rolling-horizon genetic algorithm. This algorithm adapts to risk changes in real time by employing incremental optimization of path segments, hybrid selection mechanisms, and parallel optimization of multi-objective subpopulations. Marseglia et al. [19] employed genetic algorithms within a centralized framework to optimize robot speed profiles via three strategies, minimizing both task completion time and energy consumption while ensuring collision avoidance. For the home healthcare drug delivery routing problem, Kordkheili et al. [20] proposed a model that combines vehicle and drone route optimization, solved by hybridizing an improved Benders decomposition algorithm with a genetic algorithm. Gasteratos and Karydis [21] proposed a genetic algorithm framework integrated with an mTSP solver to optimize drone launching pad placement (and consequently path planning), achieving near-optimal accuracy with minimal computational cost. Maktabifard and Földes [22] proposed a genetic algorithm solution based on an asymmetric multi-agent path-planning model for the multi-vehicle cooperative path-planning problem. Alzubairi et al. [23] proposed a hybrid path-planning method that integrates probabilistic roadmaps with an enhanced genetic algorithm by improving environmental modeling, initial population generation, and genetic operators, which outperforms traditional algorithms in both single- and multi-objective scenarios. Genetic algorithms are known for their robust global search capability. However, they lack a mechanism to fine-tune searches within high-quality solution regions. Consequently, during the later stages of evacuation route planning, when the population nears the optimum, convergence often slows as the algorithm struggles to decipher the local landscape.
Therefore, a single algorithm often cannot simultaneously deliver rapid convergence, global optimality, and an effective solution to complex path-planning problems in emergency evacuation scenarios. In recent years, researchers worldwide have attempted to fuse different algorithms to solve path-planning problems, integrating their strengths and compensating for the shortcomings of individual ones. For instance, combining the ant colony optimization algorithm with A* can accelerate the initial search, resulting in shorter and more efficient paths [24]. Lan et al. [25] integrated the ant colony optimization (ACO) algorithm with A* to minimize delivery time. Their approach used A* for obstacle avoidance and ACO to determine the drone’s optimal path, thereby achieving effective path optimization. Châari et al. [26] proposed a hybrid path-planning algorithm that integrates an improved ant colony optimization with a genetic algorithm, enhancing path selection and crossover operators to boost computational efficiency and reduce execution time. Leveraging GPS data, Raei et al. [27] developed a dynamic Dijkstra-A* algorithm that integrates distance, congestion, and fire risk into a multi-criteria cost function. They validated the effectiveness of the resulting evacuation routing strategy through SUMO simulations. Amr et al. [28] proposed an improved particle swarm optimization genetic algorithm based on Manhattan distance and vertical search strategies for mobile robot path planning. These studies demonstrate the potential of hybrid algorithms. However, existing fusion methods have primarily been applied to static logistics and UAV path planning. For personnel emergency evacuation scenarios, they lack deep integration at the algorithmic mechanism level.
In view of this, this paper presents an improved hybrid approach that integrates the ant colony optimization algorithm with the genetic algorithm to address the emergency evacuation route planning problem for underground stations. Ant colony optimization compensates for the genetic algorithm’s lack of local search precision, while the genetic algorithm effectively overcomes ACO’s initial search blindness and tendency to converge prematurely on local optima. Moreover, both algorithms are population-based iterative optimizers, which facilitates the design of a unified evaluation and selection mechanism. Compared to other integrated methods, the ACO-A* fusion tends to reduce population diversity and shows limited global search capability. Moreover, applying the ACO-PSO fusion to this study’s path-planning problem necessitates complex discrete encoding, which significantly compromises efficiency and adds unnecessary complexity. Therefore, this paper constructs a path-planning model incorporating three objective functions: to minimize total evacuation time, total route segment risk, and the panic index. A synergistic ACO-GA hybrid algorithm is proposed. It employs an enhanced ant colony optimization algorithm, featuring multidimensional pheromones and an improved heuristic function, which is then integrated with a genetic algorithm to solve the model and derive optimal evacuation routes while ensuring personnel safety.
2. Description of the Problem
The issue of emergency evacuation at subway stations in real-world scenarios is highly complex; single-objective path-planning methods struggle to meet real-time decision-making demands in intricate dynamic environments. Emergency evacuation scenarios in complex settings constitute a classic multi-objective optimization problem, requiring comprehensive consideration of multiple influencing factors. In emergency situations, factors such as evacuation conditions, incident scale, and crowd density can easily trigger panic. This emotion often leads to crowd congestion and exit blockage, thereby prolonging evacuation time. To optimize emergency evacuations, it is essential to balance evacuation time, safety, and public panic. This comprehensive approach maximizes efficiency while minimizing casualties and property damage.
This study proposes a multi-objective path planning approach for emergency evacuation in underground stations by integrating an enhanced ant colony algorithm with a genetic algorithm. This paper formulates a multi-objective path-planning model that incorporates evacuation time, road segment risk, and panic index; to strengthen the algorithm’s performance in dynamic environments, we improve the pheromone update mechanism and state transition strategy of the ant colony algorithm. This study proposes a collaborative optimization mechanism that integrates ant colony and genetic algorithms. By leveraging their complementary strengths in global and local search, simulation experiments were conducted to design three distinct evacuation scenarios across different stages, aiming to identify efficient and safe evacuation routes within complex environments, thereby enhancing overall evacuation efficiency.
3. Model Construction
3.1. Model Assumptions
- (1)
- The location of the incident is known;
- (2)
- The structure of all evacuation zones is known and remains unchanged during the evacuation process;
- (3)
- All outlets remain fully functional during emergencies;
- (4)
- The spread of panic among all personnel follows the SIR model;
- (5)
- All personnel exhibit homogeneous behavioral responses under conditions of panic, with movements adhering to identical patterns;
- (6)
- The spread of panic occurs only at nodes;
- (7)
- Pedestrians are not permitted to move back and forth during the evacuation process.
3.2. Model Variable Symbol Explanation
is the set of all nodes;
is the set of channel ;
is the total number of people in the region;
is a hazard source;
is the distance from node to node ;
is the velocity from node to node at time ;
is the inherent risk from node to node ;
is the number of people moving from node to node ;
is the number of people lingering at node ;
is the actual time taken for personnel to move from node to node ;
is the maximum capacity of edge ;
is the decision variable, and it indicates whether pedestrian is present on segment ;
is the susceptible proportion at node and time ;
is the panicked proportion at node and time ;
is the recovered proportion at node and time ;
is the total number of people at node and time ;
is panic infection rate at node and time ;
is the base infection rate of panic sentiment;
is the recovery rate of panic sentiment;
is the density influence coefficient;
is the coefficient of inhibition of panic on speed, ;
is the amplification factor of panic sentiment on risk.
3.3. Mathematical Model
Given the complex environment, personnel distribution, and varying panic levels during metro station emergencies, it is necessary to incorporate the SIR model to characterize the dynamics of evacuee panic throughout the evacuation process. Currently, SI, SIR, and SIRS transmission models are widely applied in evacuation modeling. The susceptible–infected(SI) [29], susceptible–infected–recovered(SIR) [30], and susceptible–infected–recovered-susceptible(SIRS) [31] models differ in their state transition assumptions. For instance, the SI model assumes individuals remain in a constant infected state, which does not reflect realistic evacuation dynamics. The SIR framework corresponds to our defined panic dynamics, thereby capturing the sentiment’s onset, spread, and the lasting behaviors it triggers. The SIRS model extends the SIR framework by allowing recovered individuals to become susceptible again, reflecting the possibility of renewed panic upon repeated risk exposure during evacuation. However, this re-susceptibility mechanism is not a primary focus in the present study.
Therefore, this paper employs the SIR model to characterize panic propagation among pedestrians. To this end, a path-planning model for metro station evacuation is constructed, using a multi-objective function that integrates evacuation time, section risk, and the panic index.
3.3.1. Shortest Total Evacuation Time Function
The paramount objective in any emergency evacuation is to ensure the immediate and orderly movement of all individuals from hazardous to safe zones. This is fundamental to safeguarding lives and minimizing property damage. To quantitatively achieve this goal of temporal efficiency, this paper formally constructs an optimization function aimed at minimizing the total evacuation time. The mathematical expression for this objective function is provided in Equation (1).
3.3.2. Minimum Total Segment Risk Function
In the event of an emergency at a metro station, evacuation procedures are accompanied by complex and variable risk factors. Therefore, this paper constructs a minimum total route segment risk function, whose mathematical expression is shown in Equation (2).
3.3.3. Minimum Personnel Panic Index Function
The complex, confined environment of a subway station significantly amplifies psychological stress, making pedestrians highly susceptible to panic during emergencies. Once initiated, panic acts as a critical behavioral disruptor: it spreads rapidly through the crowd, compromises rational decision-making, and triggers competitive behaviors. This leads to chaotic crowding and bottlenecks, which severely impede evacuation efficiency. Therefore, to reduce potential casualties during evacuation and enhance evacuation efficiency, this paper constructs a minimal panic index function, whose mathematical expression is shown in Equation (3).
In summary, the multi-objective path-planning model developed in this study is summarized as follows:
In this equation, is the weighting coefficient for evacuation time, is the weighting coefficient for road segment risk, is the weighting coefficient of the fear index, and .
Among these, Equation (5) defines the initial states of personnel flow and panic at the initial moment. Equation (6) specifies that the evacuee count through any passage must remain below its carrying capacity at any given moment, and the population at any node must not exceed the node’s capacity. Equation (7) states that each person can select only one evacuation path at a time and that all flow quantities are non-negative. Equation (8) states that the total number of people entering and exiting the evacuation network remains constant. Equation (9) defines the total evacuated population from the hazard source. Equation (10) ensures that all evacuees ultimately arrive at the safe zone. Equation (11) expresses the relationship between panic infection rate and population density. Equation (12) represents the propagation process of panic sentiment within the region.
4. Hybrid Algorithm Design
4.1. Improved Ant Colony Optimization
4.1.1. Improved Pheromone Refresh Rules
Traditional ant colony optimization is characterized by slow convergence and a susceptibility to local optima, as well as by suboptimal multi-objective weight allocation and a lack of global search capability. Personnel evacuation requires the simultaneous optimization of multiple objectives: evacuation time, path risk, and the panic index. Traditional ant colony optimization employs a fixed-weight summation method. This makes it ill-suited to adapt to dynamic environmental changes. To achieve simultaneous optimization of multiple objectives, the pheromone update mechanism in ant colony optimization requires multi-objective fitness optimization. After an ant completes a search cycle, the pheromone along its path is updated. This paper will design a multidimensional pheromone system, assigning distinct pheromones to each target. The improved pheromone update rule is given by Equation (13).
In this equation, is the pheromone volatilization coefficient, denotes the pheromone increment induced by ant on path in target dimension , as shown in Equation (14).
In this equation, is the pheromone intensity coefficient, is the path value of Ant at target , and is the dynamic weight of path at time . When the crowd density along path is relatively high, the weight should be appropriately reduced to decrease the probability of selecting that route.
4.1.2. Improved State Transition Probability
In traditional ant colony optimization, the heuristic function is typically the inverse of the inter-node distance. This distance-based heuristic guidance strategy causes ants to exhibit a pronounced tendency toward local optima during path selection, thereby struggling in the multi-objective, dynamic, and complex environment of emergency evacuation planning. To address this issue, an adaptive heuristic function is proposed that incorporates multiple objective factors: evacuation time, risk, and panic sentiment, with the heuristic function defined as shown in Equation (15).
In this equation, is the Euclidean distance from the current node to the next node ; is the safety risk coefficient for road segment , and ; is the proportion of personnel in a state of panic at the target node at time ; , , and represent distance, risk, and panic weightings, respectively, and ; the parameter represents the panic influence coefficient. The higher the value, the more sensitive ants are to panic and the more inclined they are to avoid panic nodes.
This paper improves the state transition probability formula of the classic ant colony optimization by integrating multi-objective pheromones with heuristic information. This allows ants to evaluate paths comprehensively during route selection, leading to more realistic evacuation decisions. The improved state transition probability formula is shown in Equation (16).
In this equation, is the pheromone heuristic factor; is the expected heuristic factor for heuristic information.
4.2. Fusion of Improved Ant Colony Optimization and Genetic Algorithm
Traditional single algorithms often face inherent limitations in achieving global optimization. Taking the genetic algorithm (GA) as an example, while this heuristic method excels in global search and avoids local optima, its performance and convergence rate can be considerably affected when handling complex problems. To overcome these challenges, this paper integrates the ant colony optimization (ACO) algorithm with the GA. This synergistic combination leverages GA’s strength in global exploration and ACO’s capability in local refinement. By harnessing their complementary advantages, the proposed hybrid approach aims to deliver more efficient and accurate solutions for complex path-planning tasks.
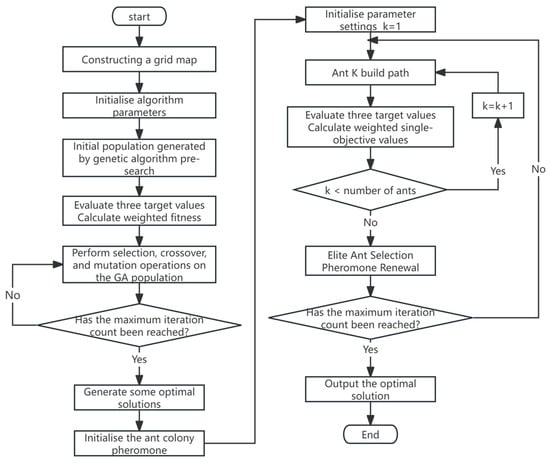
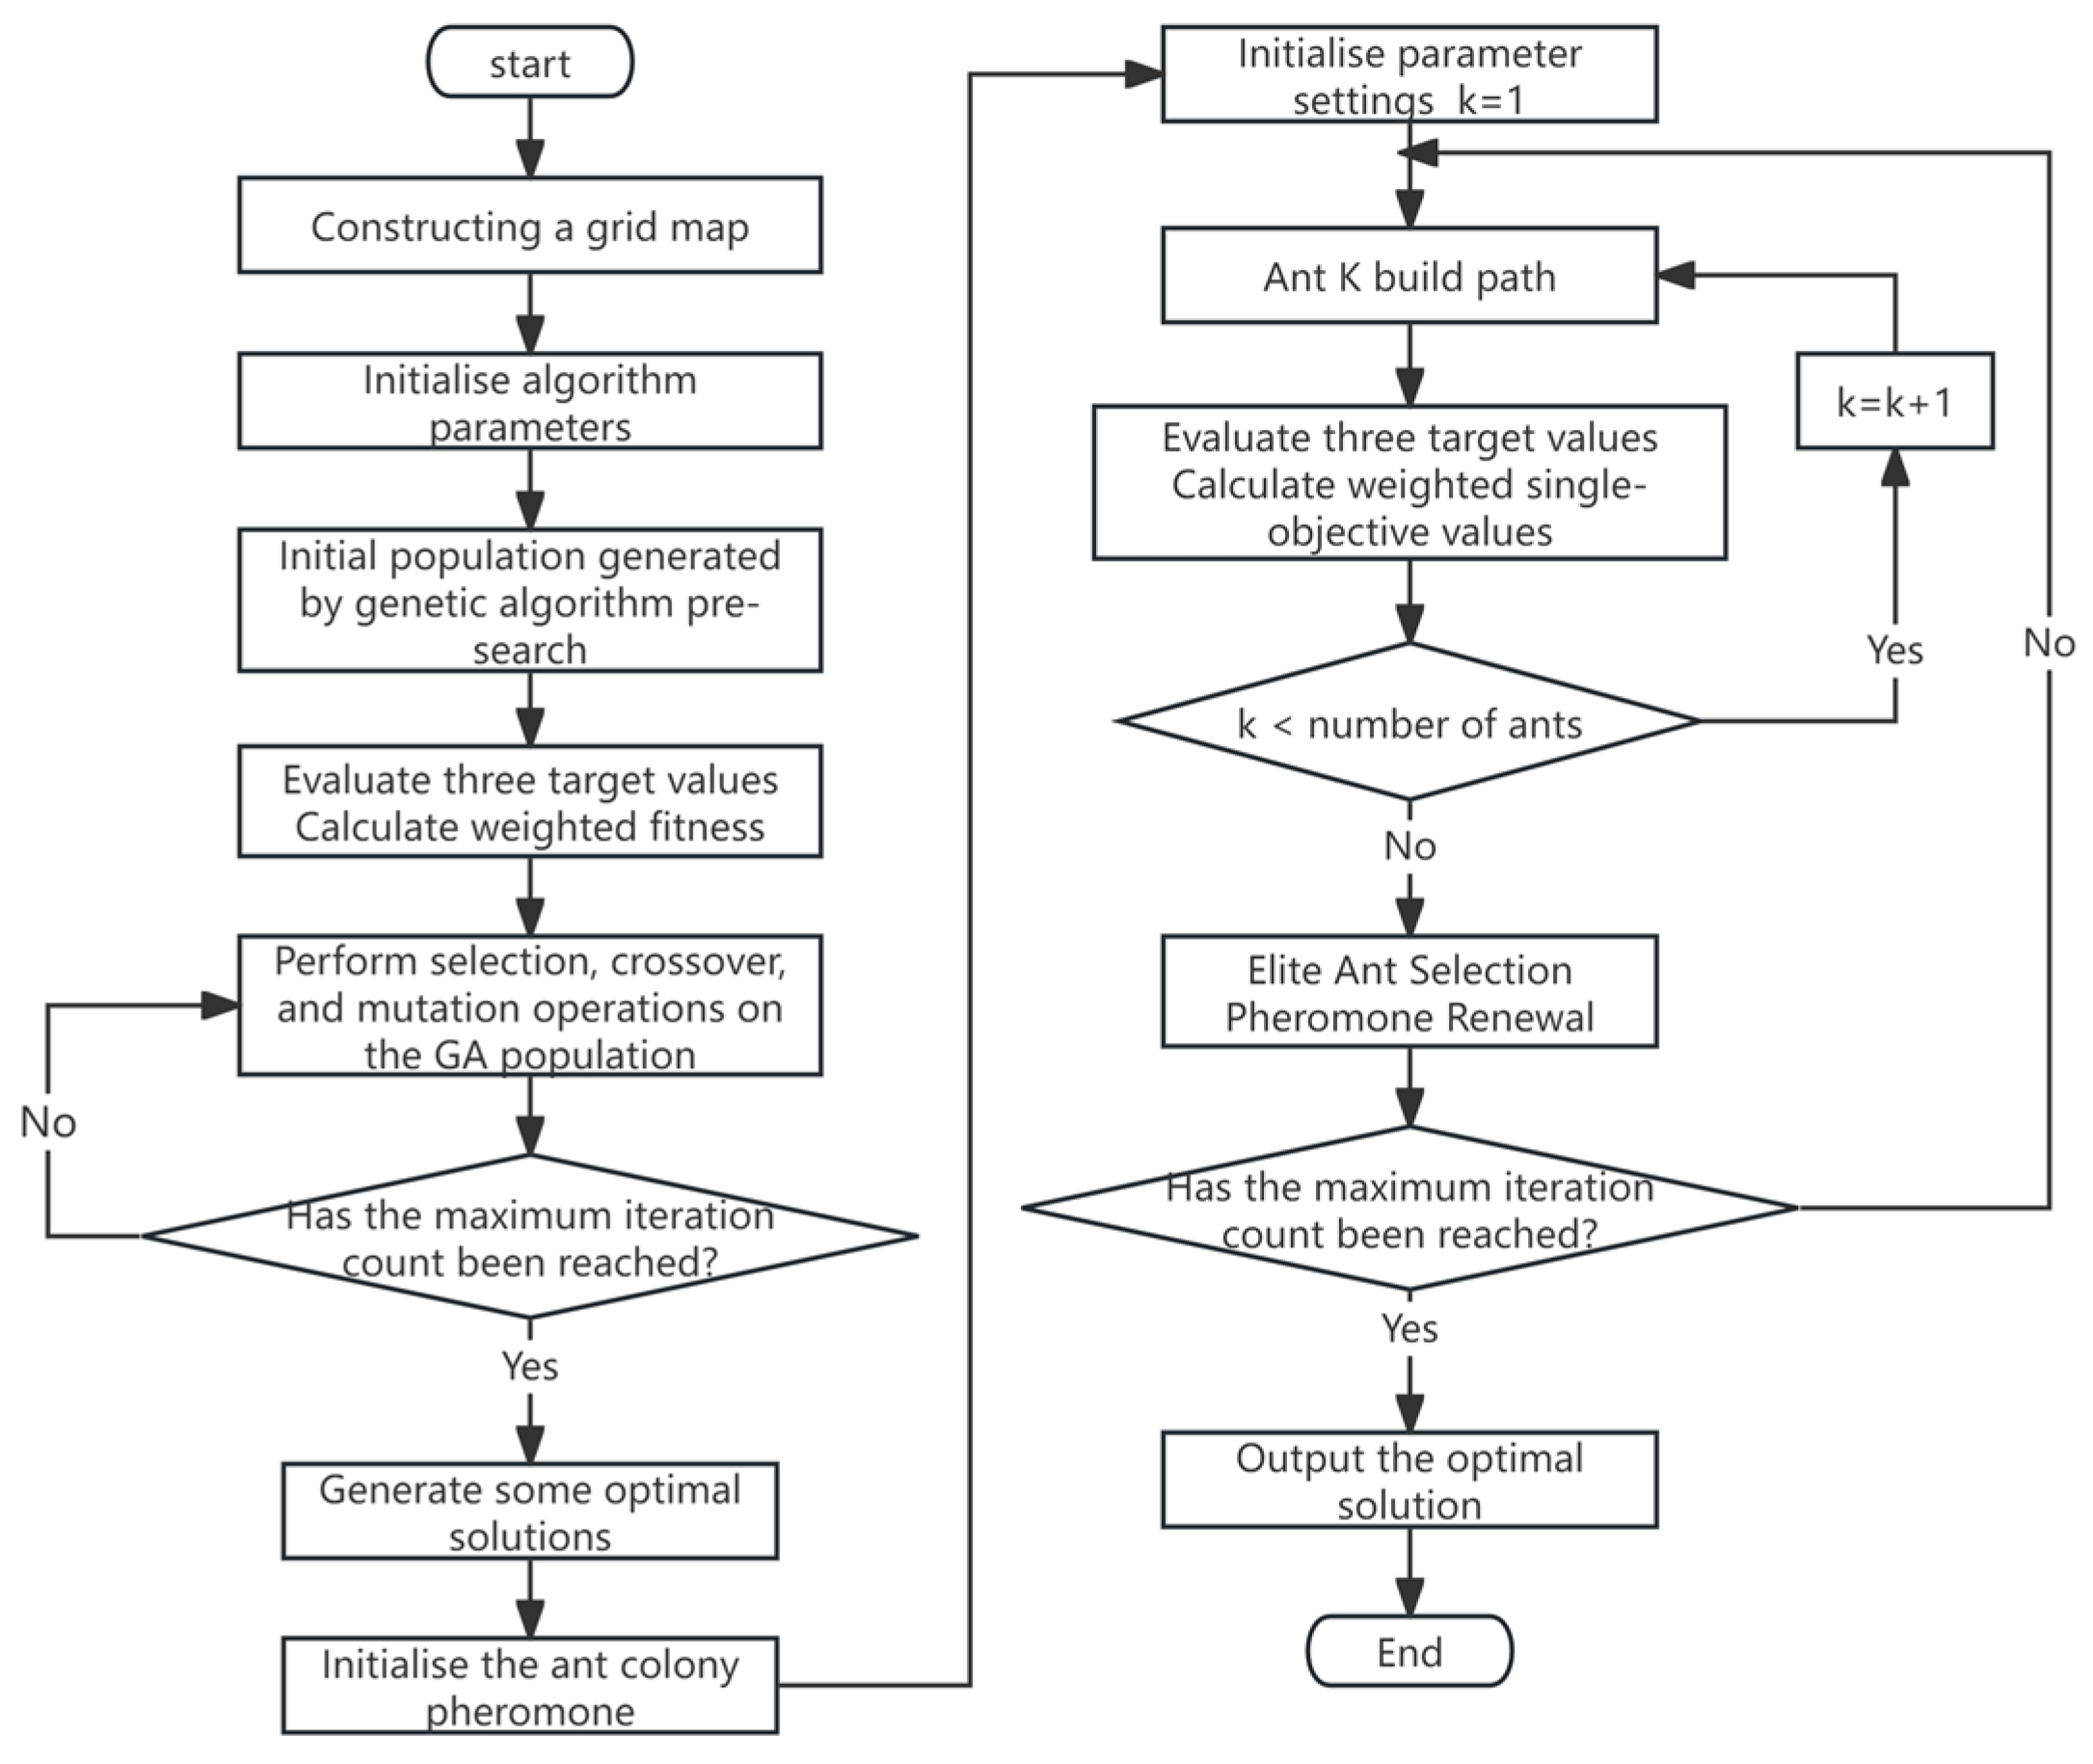
The proposed hybrid algorithm operates in two stages: a genetic algorithm pre-search stage, followed by an ant colony algorithm optimization stage. In the genetic algorithm’s pre-search phase, a set of initial path solutions is randomly generated, each representing a feasible evacuation route. During this phase, three objective function values are computed for every path and combined into a composite fitness score via weighted summation. Genetic operations are subsequently applied to evolve these solutions toward optimality. In the ant colony optimization phase, the optimal solution set derived from the genetic algorithm serves as the initial pheromone distribution. Ant constructs paths based on improved state transition probabilities, calculates the three objective values for each path, and weights them to form a single evaluation metric. Determine whether is less than the total number of ants: if so, increment by one and proceed to construct the path for the next ant. Otherwise, all ants have completed their tours for this iteration, and the algorithm proceeds to the pheromone update phase. Then, elite ant selection and pheromone updates are performed. The algorithm checks if the maximum iteration count has been reached; if so, it terminates and outputs the optimal solution. The flowchart of the proposed hybrid improved ACO-GA (IACO-GA) algorithm for multi-objective path planning is presented in Figure 1.
Figure 1.
Flowchart of the IACO-GA.
5. Simulation Experiments and Validation
5.1. Environment Setup
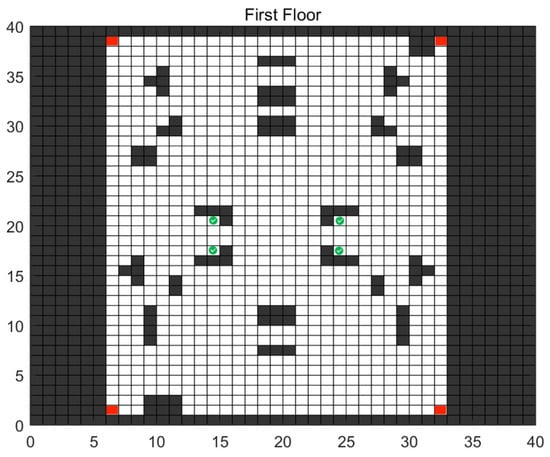
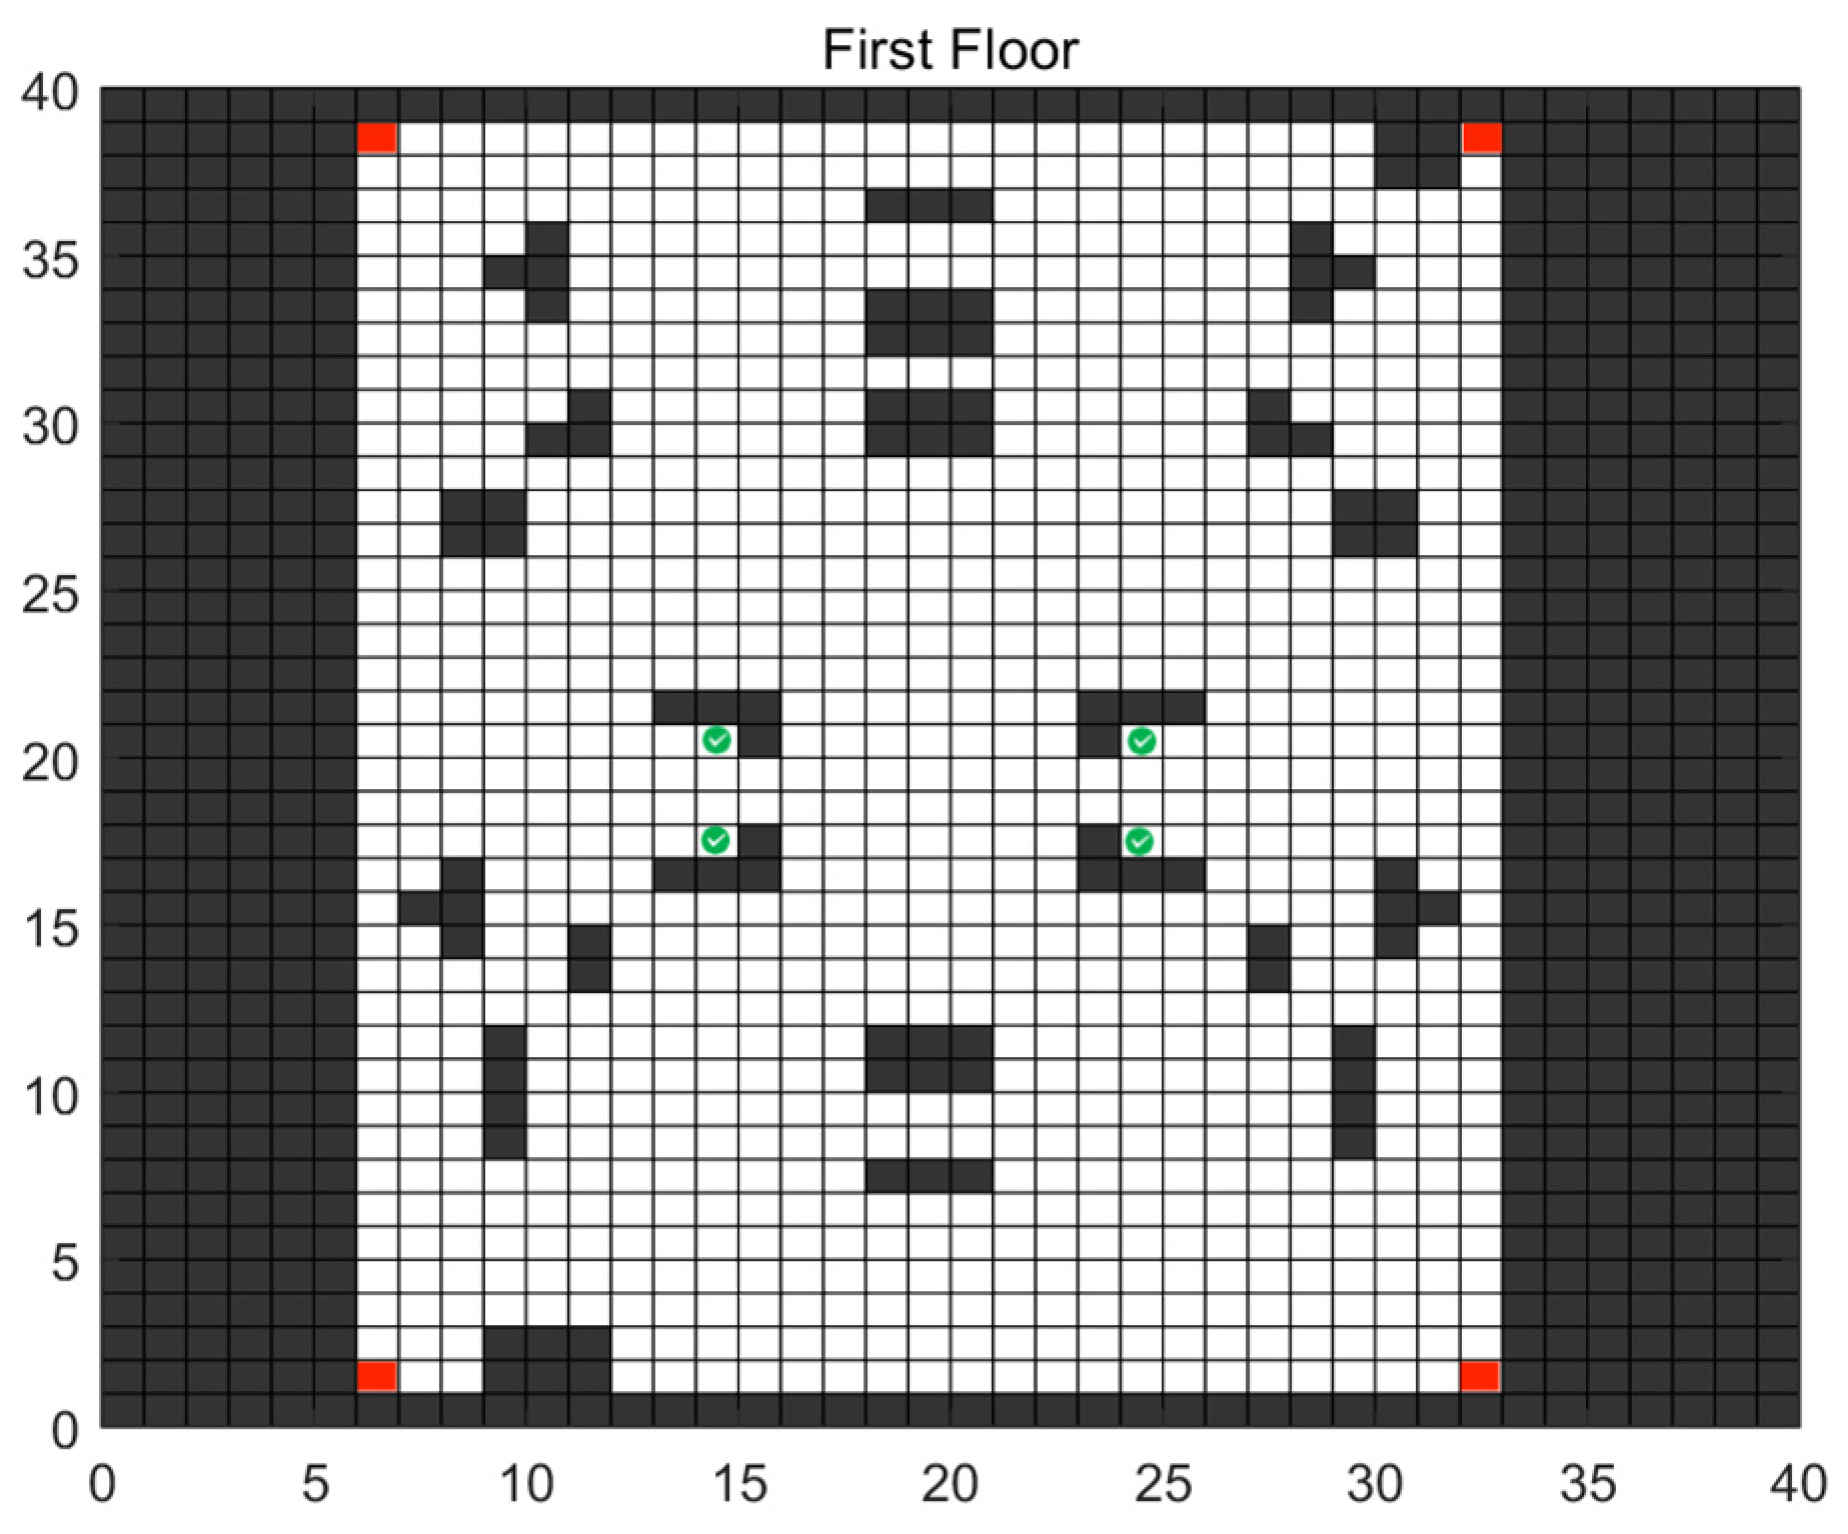
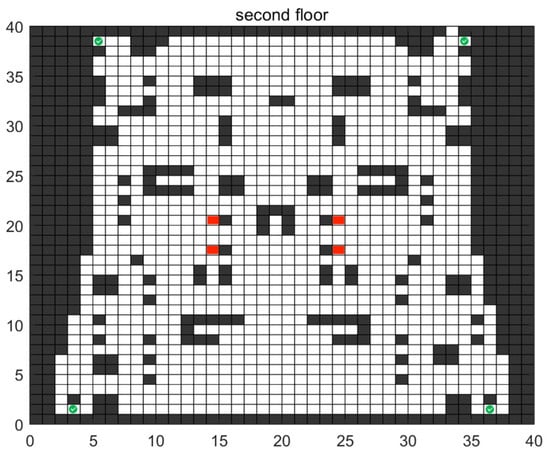
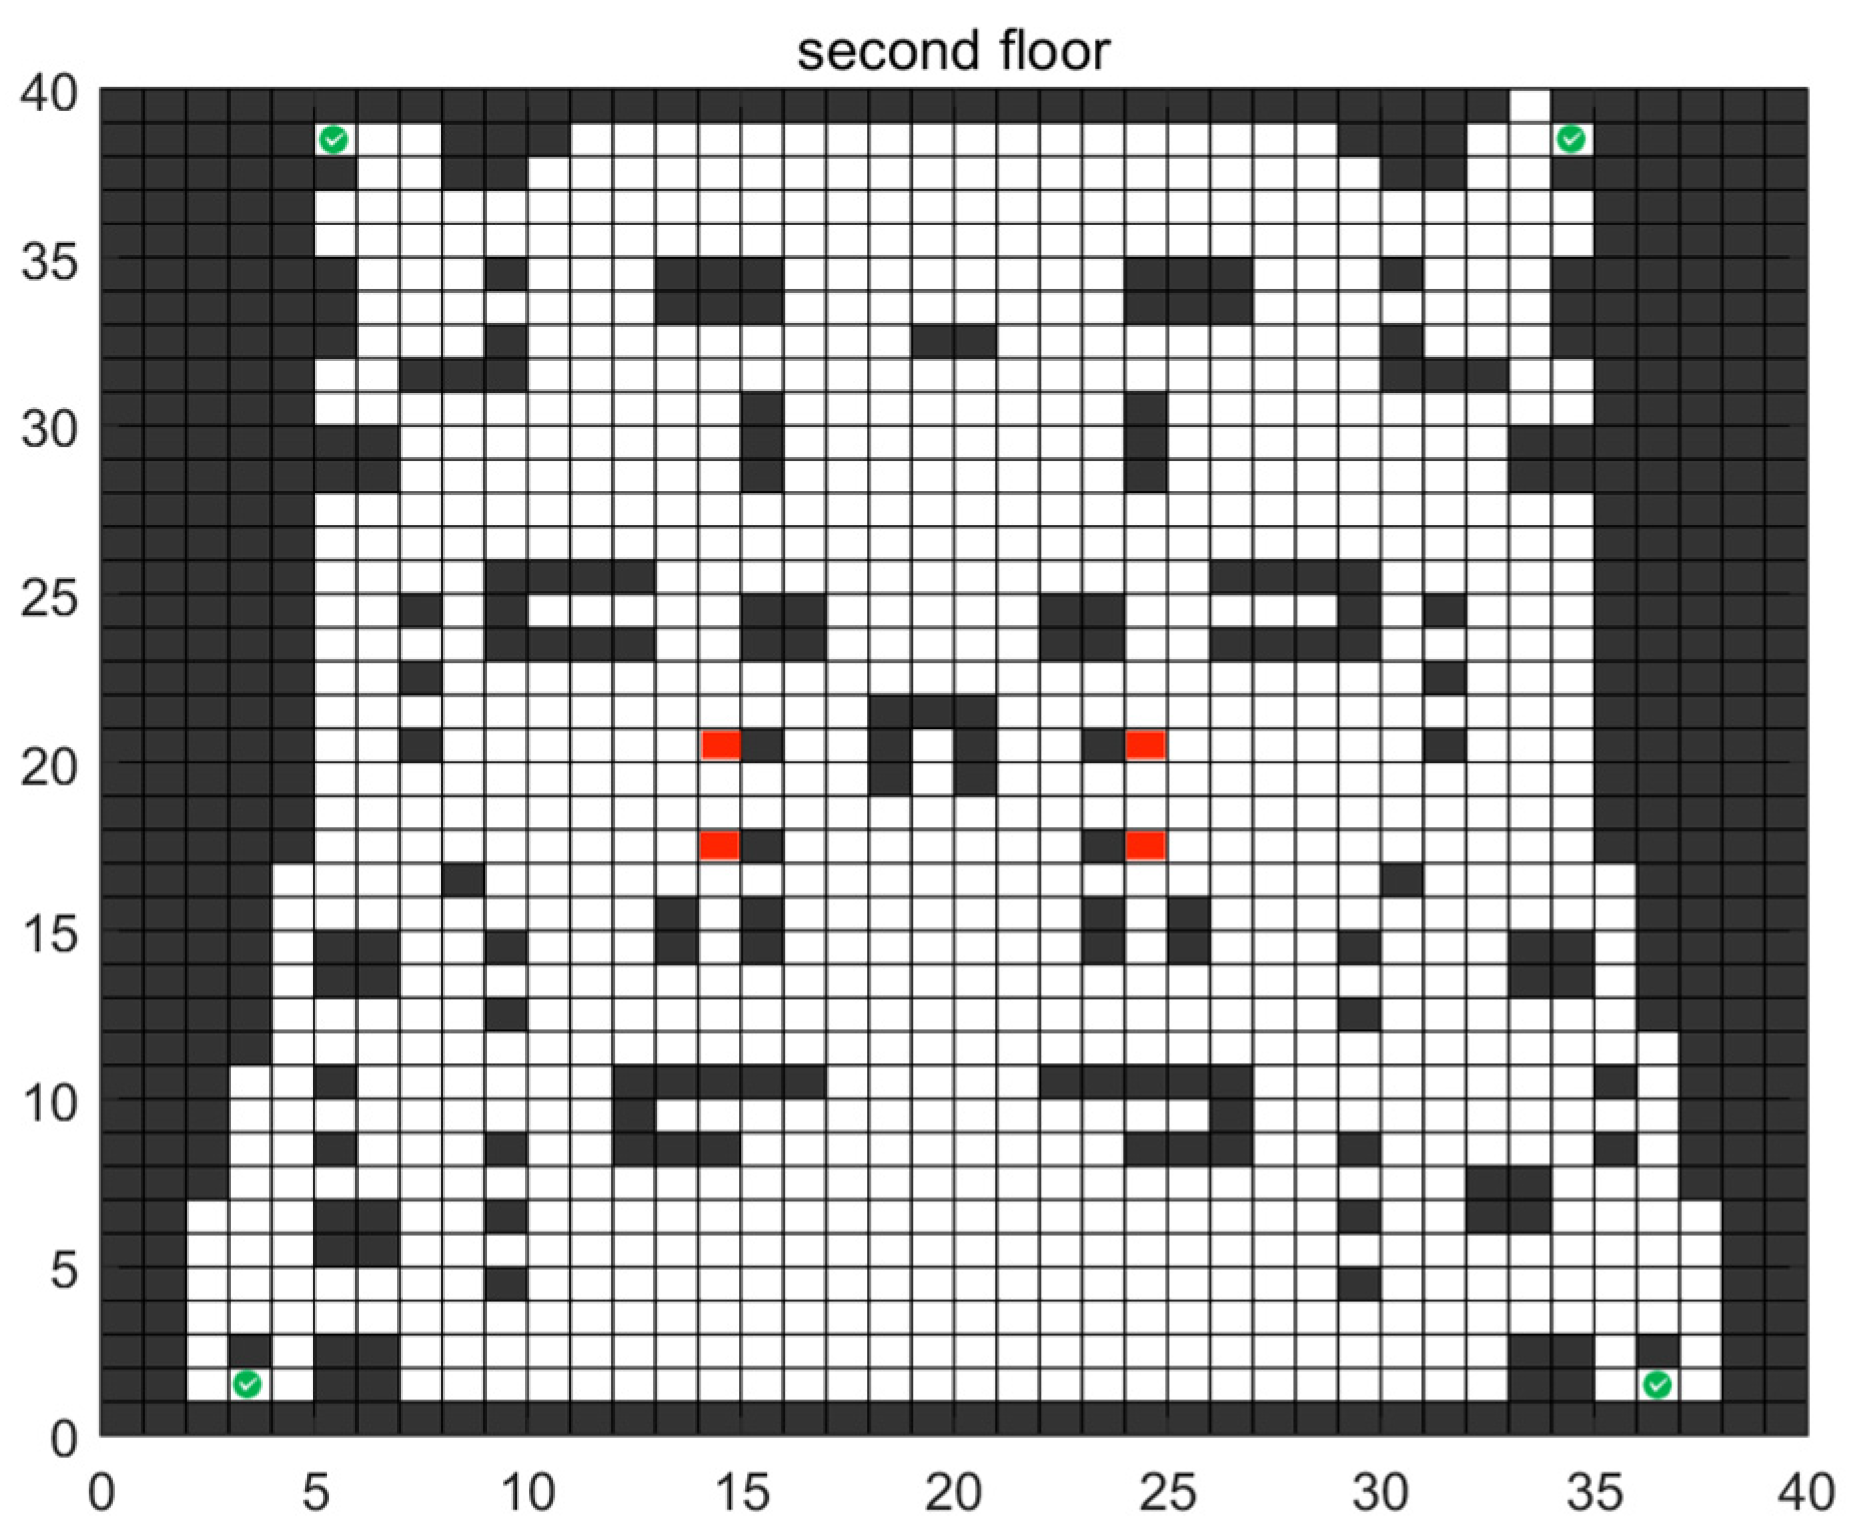
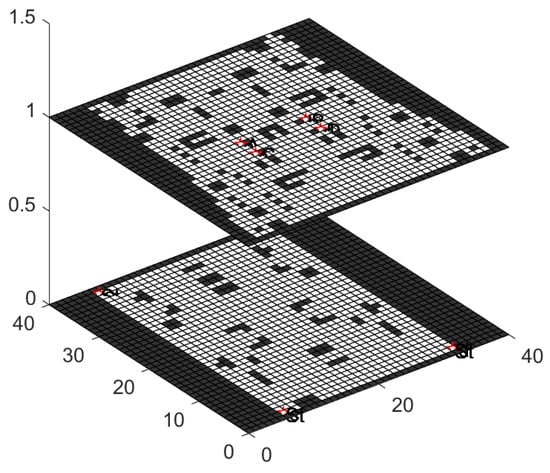
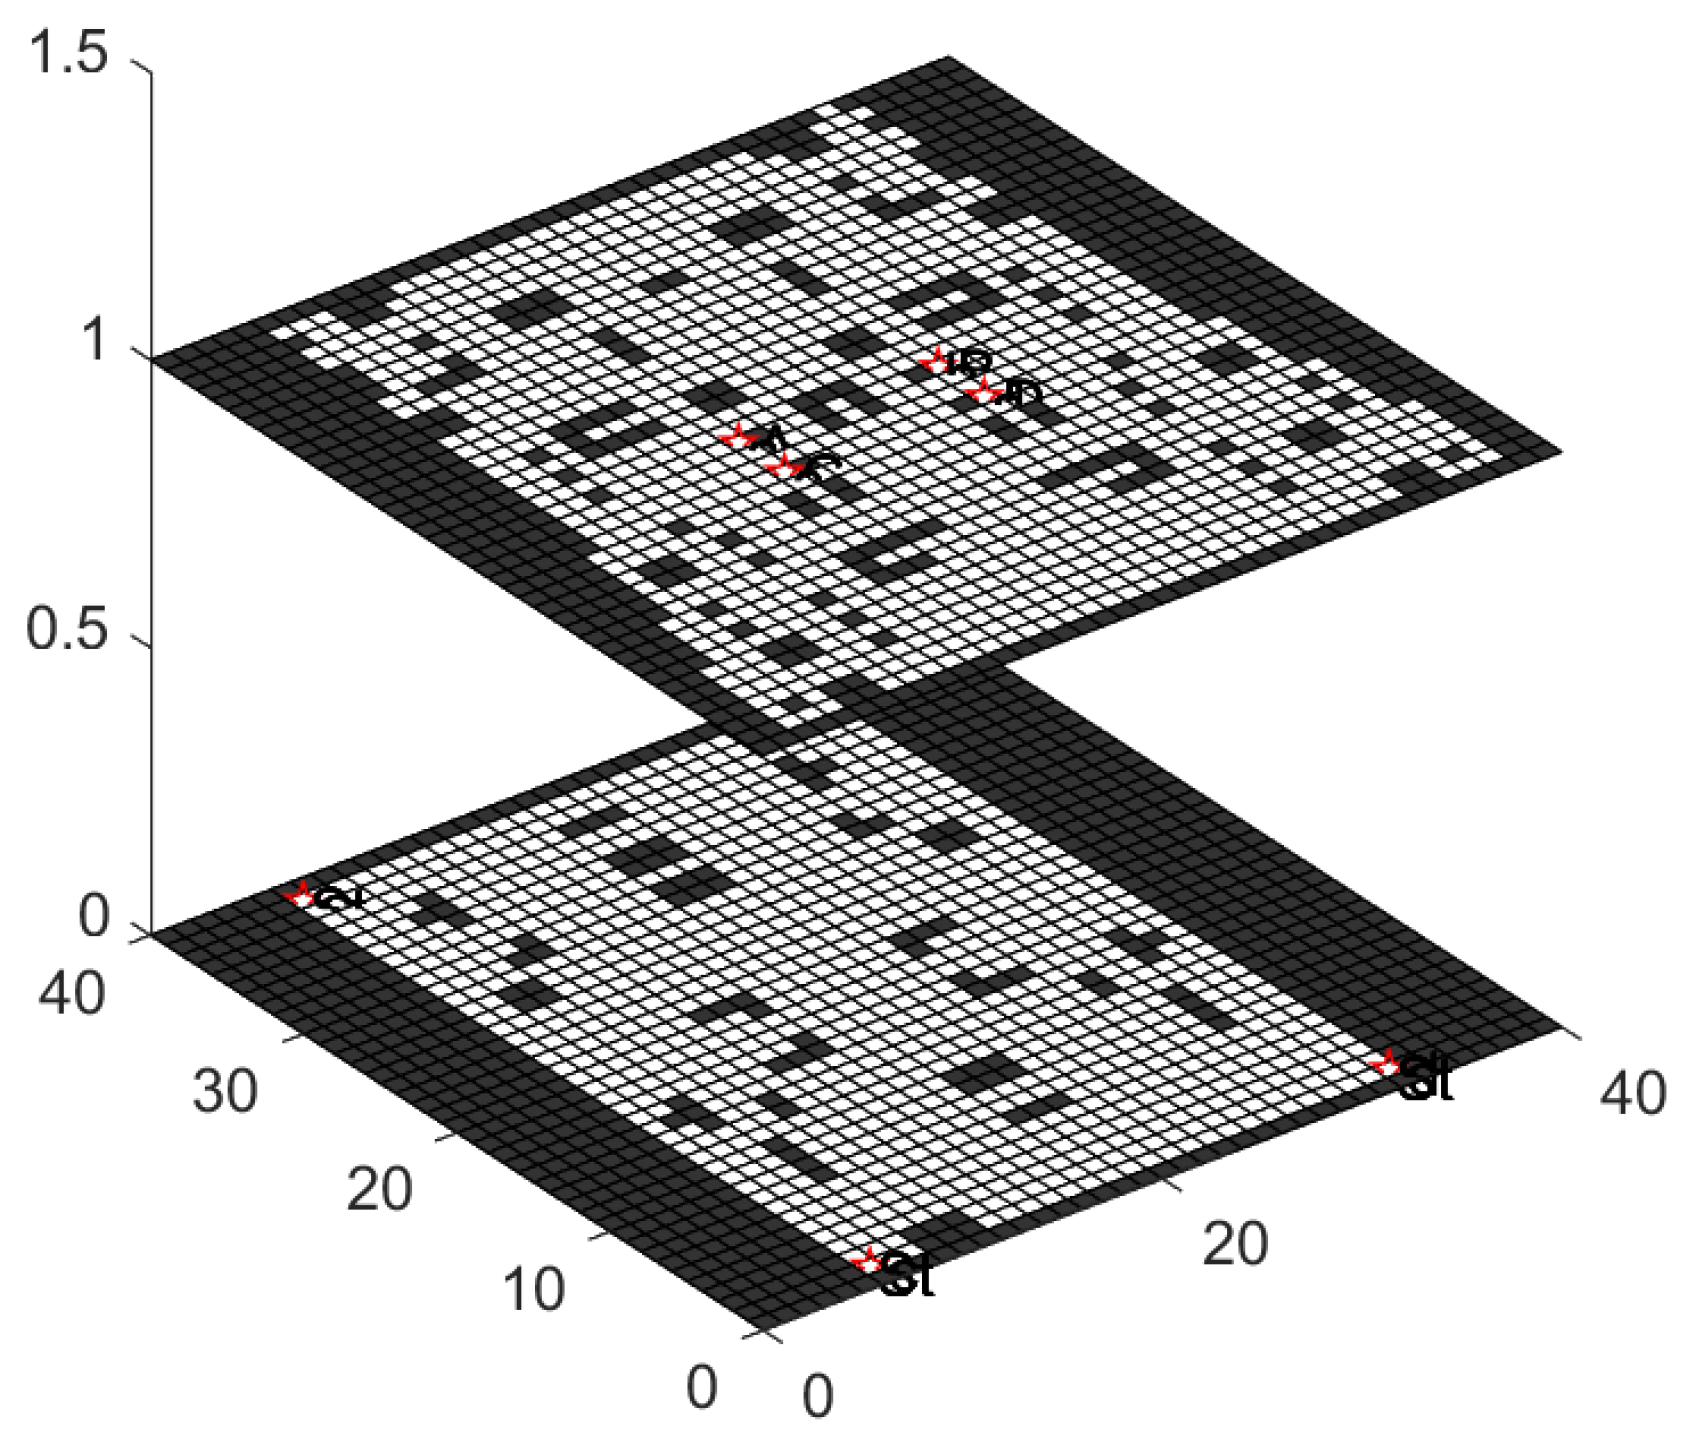
The evacuation scenario uses a simplified model of subway station A, which comprises two levels: the platform and the concourse. For this purpose, the station layout is simplified, with each floor represented as a separate 40 × 40 2D grid. On the map, the first level is the platform level, with four exits leading to the second level. Red markers indicate evacuation starting points on the first level, while green markers indicate evacuation end points, as shown in Figure 2. The second level is the station concourse. As shown in Figure 3, hazardous sources are located here. Evacuation on this level continues from the exits connected to the platform level (now marked as red starting points) toward the final station exits (marked in green). These grids are then combined to form the 3D simulation model shown in Figure 4. The pentagrams in the diagram indicates the outlet. Under this setup, the primary objective of path planning is to ensure a safe and efficient evacuation for all individuals from any starting point on the platform level to the final exits on the concourse level.
Figure 2.
Floor plan of level 1 at subway station A.
Figure 3.
Floor plan of level 2 at subway station A.
Figure 4.
Three-dimensional architectural drawings.
5.2. Parameter Settings
Prior to the experimental runs, the algorithm parameters were tuned. To account for the differing priorities among objectives, the Saaty nine-point scale method was used for pairwise comparisons of the criteria, forming the judgment matrix A. Based on the judgment matrix, the eigenvectors were computed using yaahp 10.3 software to derive criterion weights. After confirming consistency (CR < 0.1), three weighting schemes were designed for different scenarios.
The weighting schemes designed for different scenarios are shown in Table 1.
Table 1.
Weighting settings.
The key parameters for the simulation experiments were determined based on a review of GA [32] and ACO [33] literature, supplemented by preliminary testing. The performance of ant colony algorithms depends on several key parameters. However, these parameters cannot be directly determined; their optimal values must be obtained through empirical tuning. To analyze the impact of individual parameters on algorithm performance, we designed controlled experiments varying , , and while keeping all other parameters constant. To ensure robustness, ten independent runs were conducted for each parameter set across all scenarios, and the results were averaged. Taking the two-layer evacuation scenario during the hazard source diffusion phase as an example, the specific experimental results are shown in Table 2.
Table 2.
Algorithm parameter tuning.
As shown in Table 2, the shortest path is obtained when , , and are set to 1.0, 3, and 0.3, respectively. The specific parameter settings are detailed in Table 3.
Table 3.
Algorithm parameter settings.
5.3. Multi-Objective Path Planning Simulation
To validate the algorithm’s effectiveness, three typical scenarios were constructed based on hazard evolution logic: the initial emergence, growth, and comprehensive diffusion stages. For each scenario, dynamic adjustments and optimizations of evacuation routes were performed. Meanwhile, the Sparrow Search Algorithm (SSA) is widely used in path planning for its simplicity and practical advantages [34]. Therefore, the fusion algorithm’s superiority was evaluated by comparing four methods: ACO, IACO, IACO-GA, and SSA.
- (1)
- The initial emergence stage of hazard sources
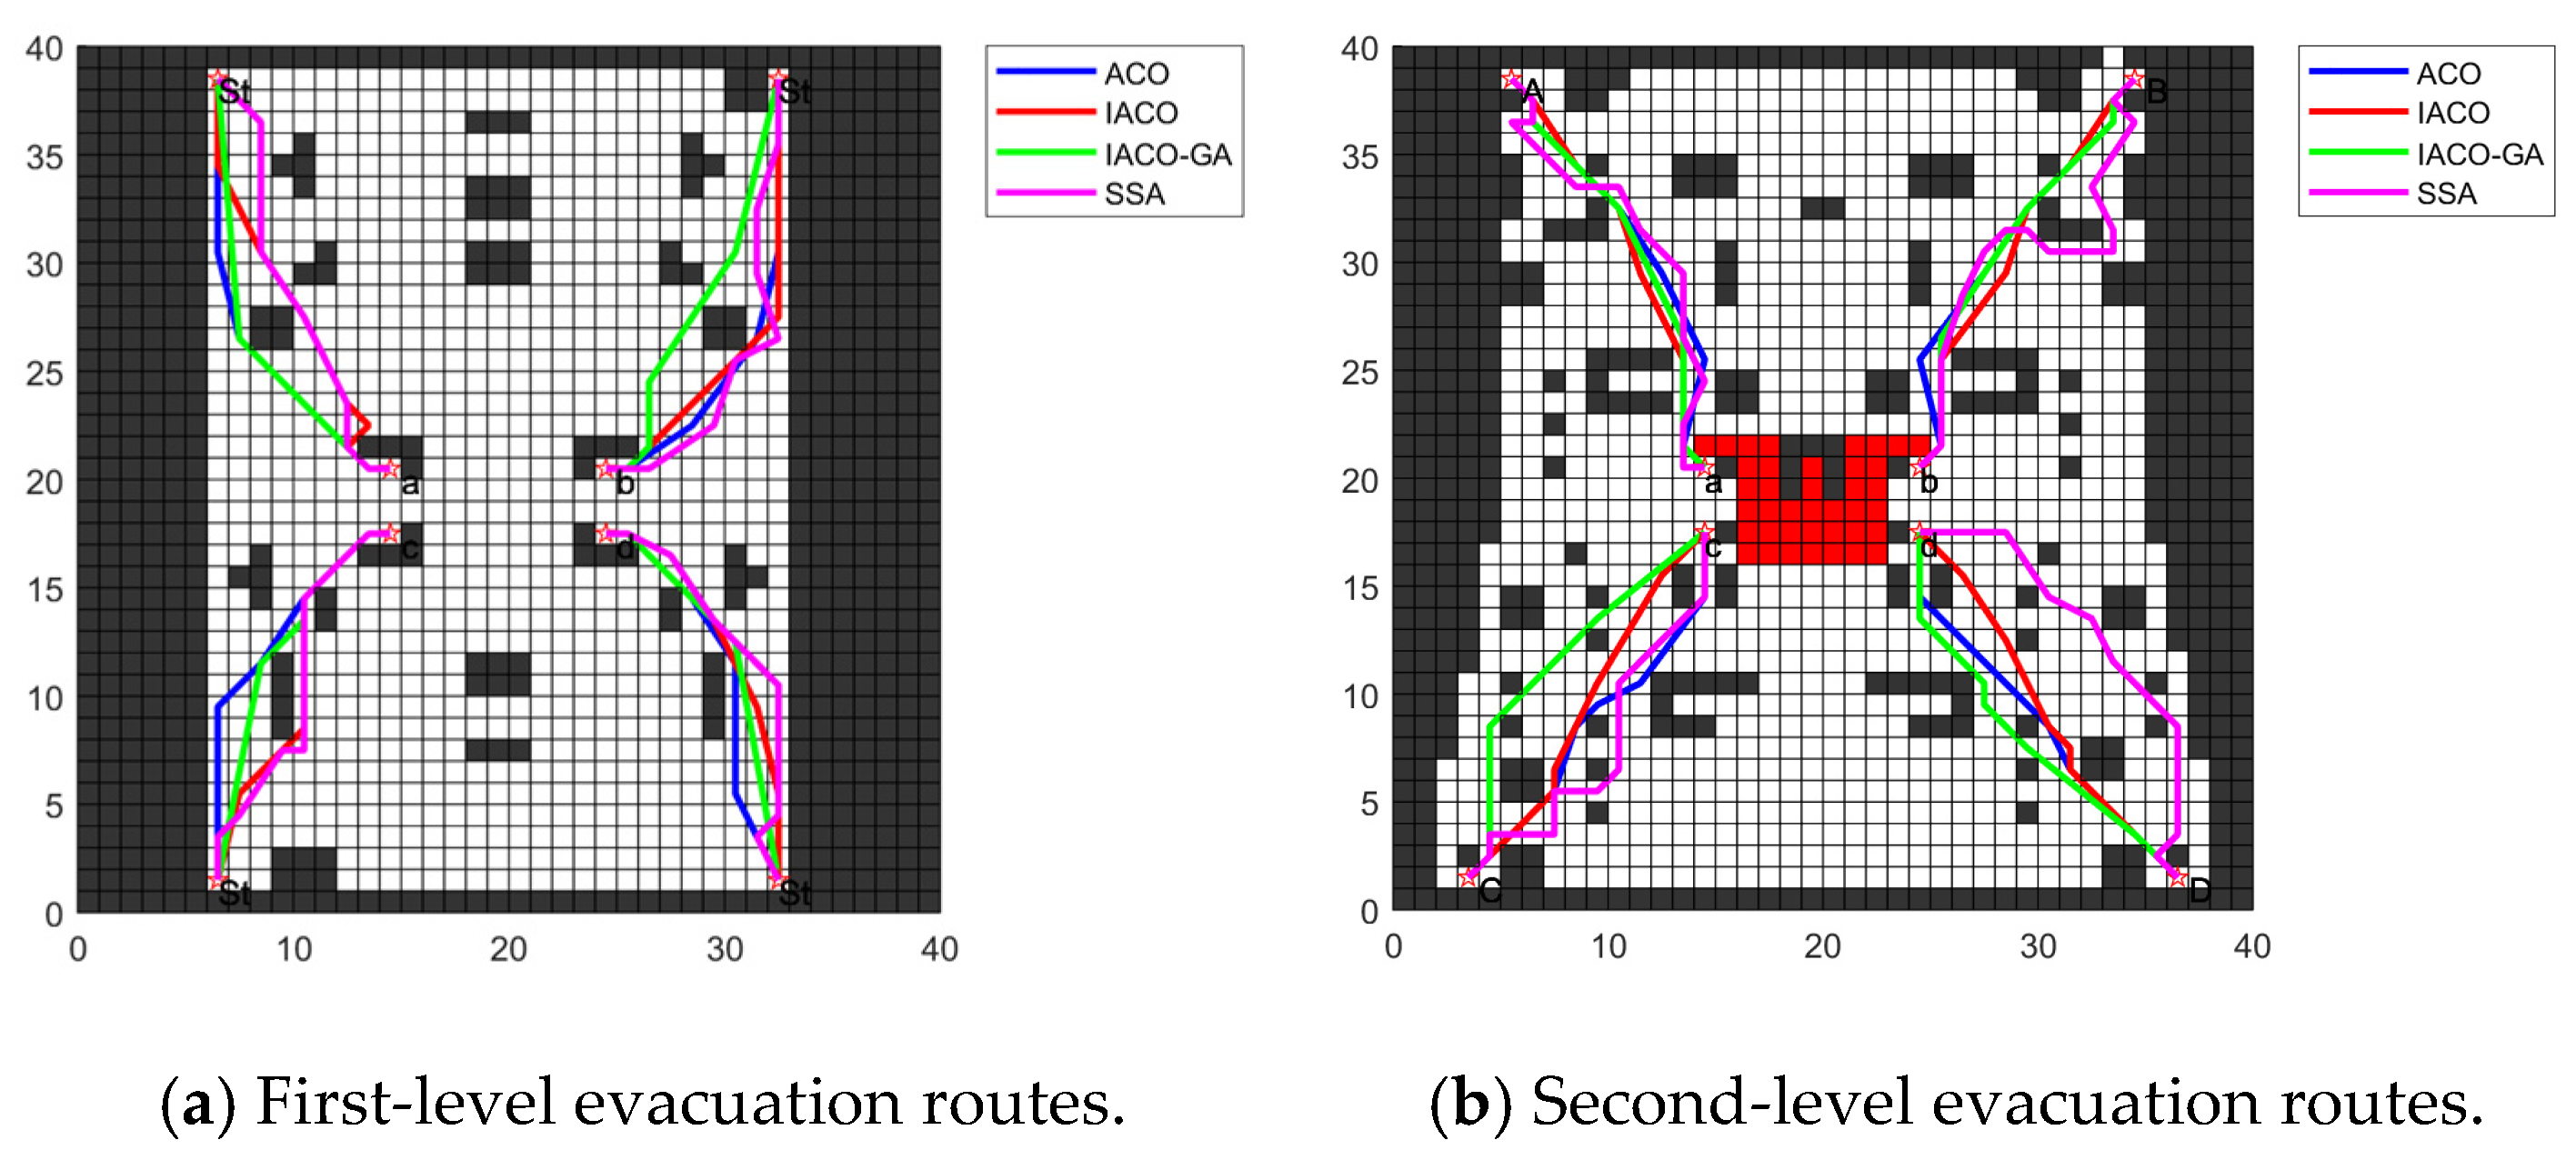
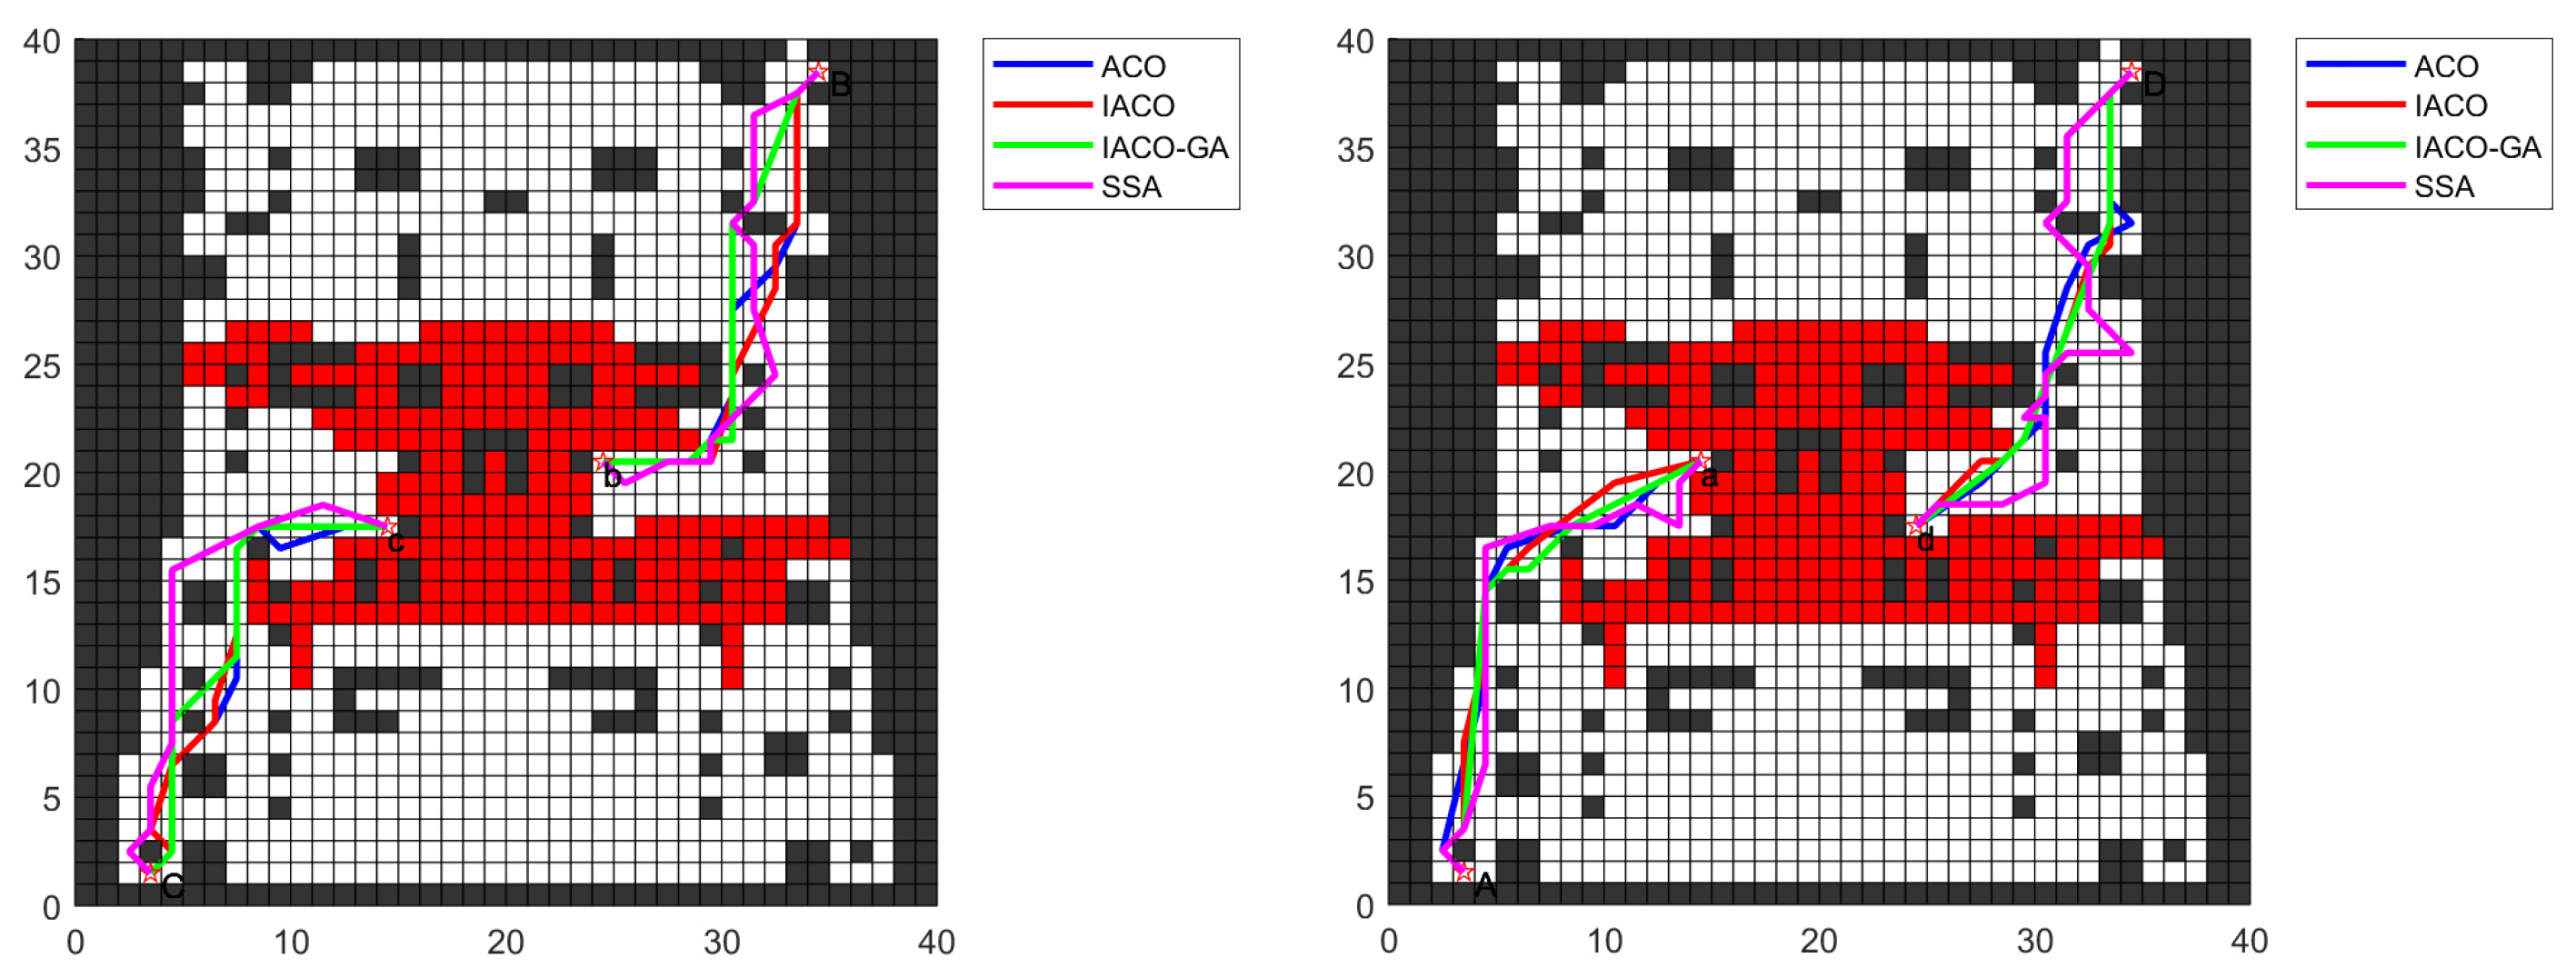
When a hazard is detected or an alarm sounds, personnel experience mild agitation and begin preparing to evacuate. In this initial stage, the emergencies have a relatively minor impact on movement speed. The corresponding evacuation routes are shown in Figure 5. Figure 5a,b show the first- and second-level evacuation routes. In the figure, the line colors correspond to the algorithms: blue for baseline ACO, red for improved ACO, purple for SSA, and green for the integrated IACO-GA.
Figure 5.
Personnel evacuation routes during the initial detection phase of hazard sources.
As shown in Figure 5, the diagram labels St as the starting point for personnel evacuation on the first floor. Points a, b, c, and d serve as evacuation exits on the first floor and also function as evacuation points on the second floor. Points A, B, C, and D are evacuation exits on the second floor. In the figure, ACO, IACO, SSA and IACO-GA can all identify the four optimal paths. However, the fusion algorithm finds paths with lower risk, less panic, and shorter distances, thereby improving evacuation efficiency. The resulting optimal path lengths for both floors are detailed in Table 4 and Table 5.
Table 4.
Comparison of optimal path lengths for personnel evacuation on the first floor.
Table 5.
Comparison of optimal path lengths for personnel evacuation on the second floor.
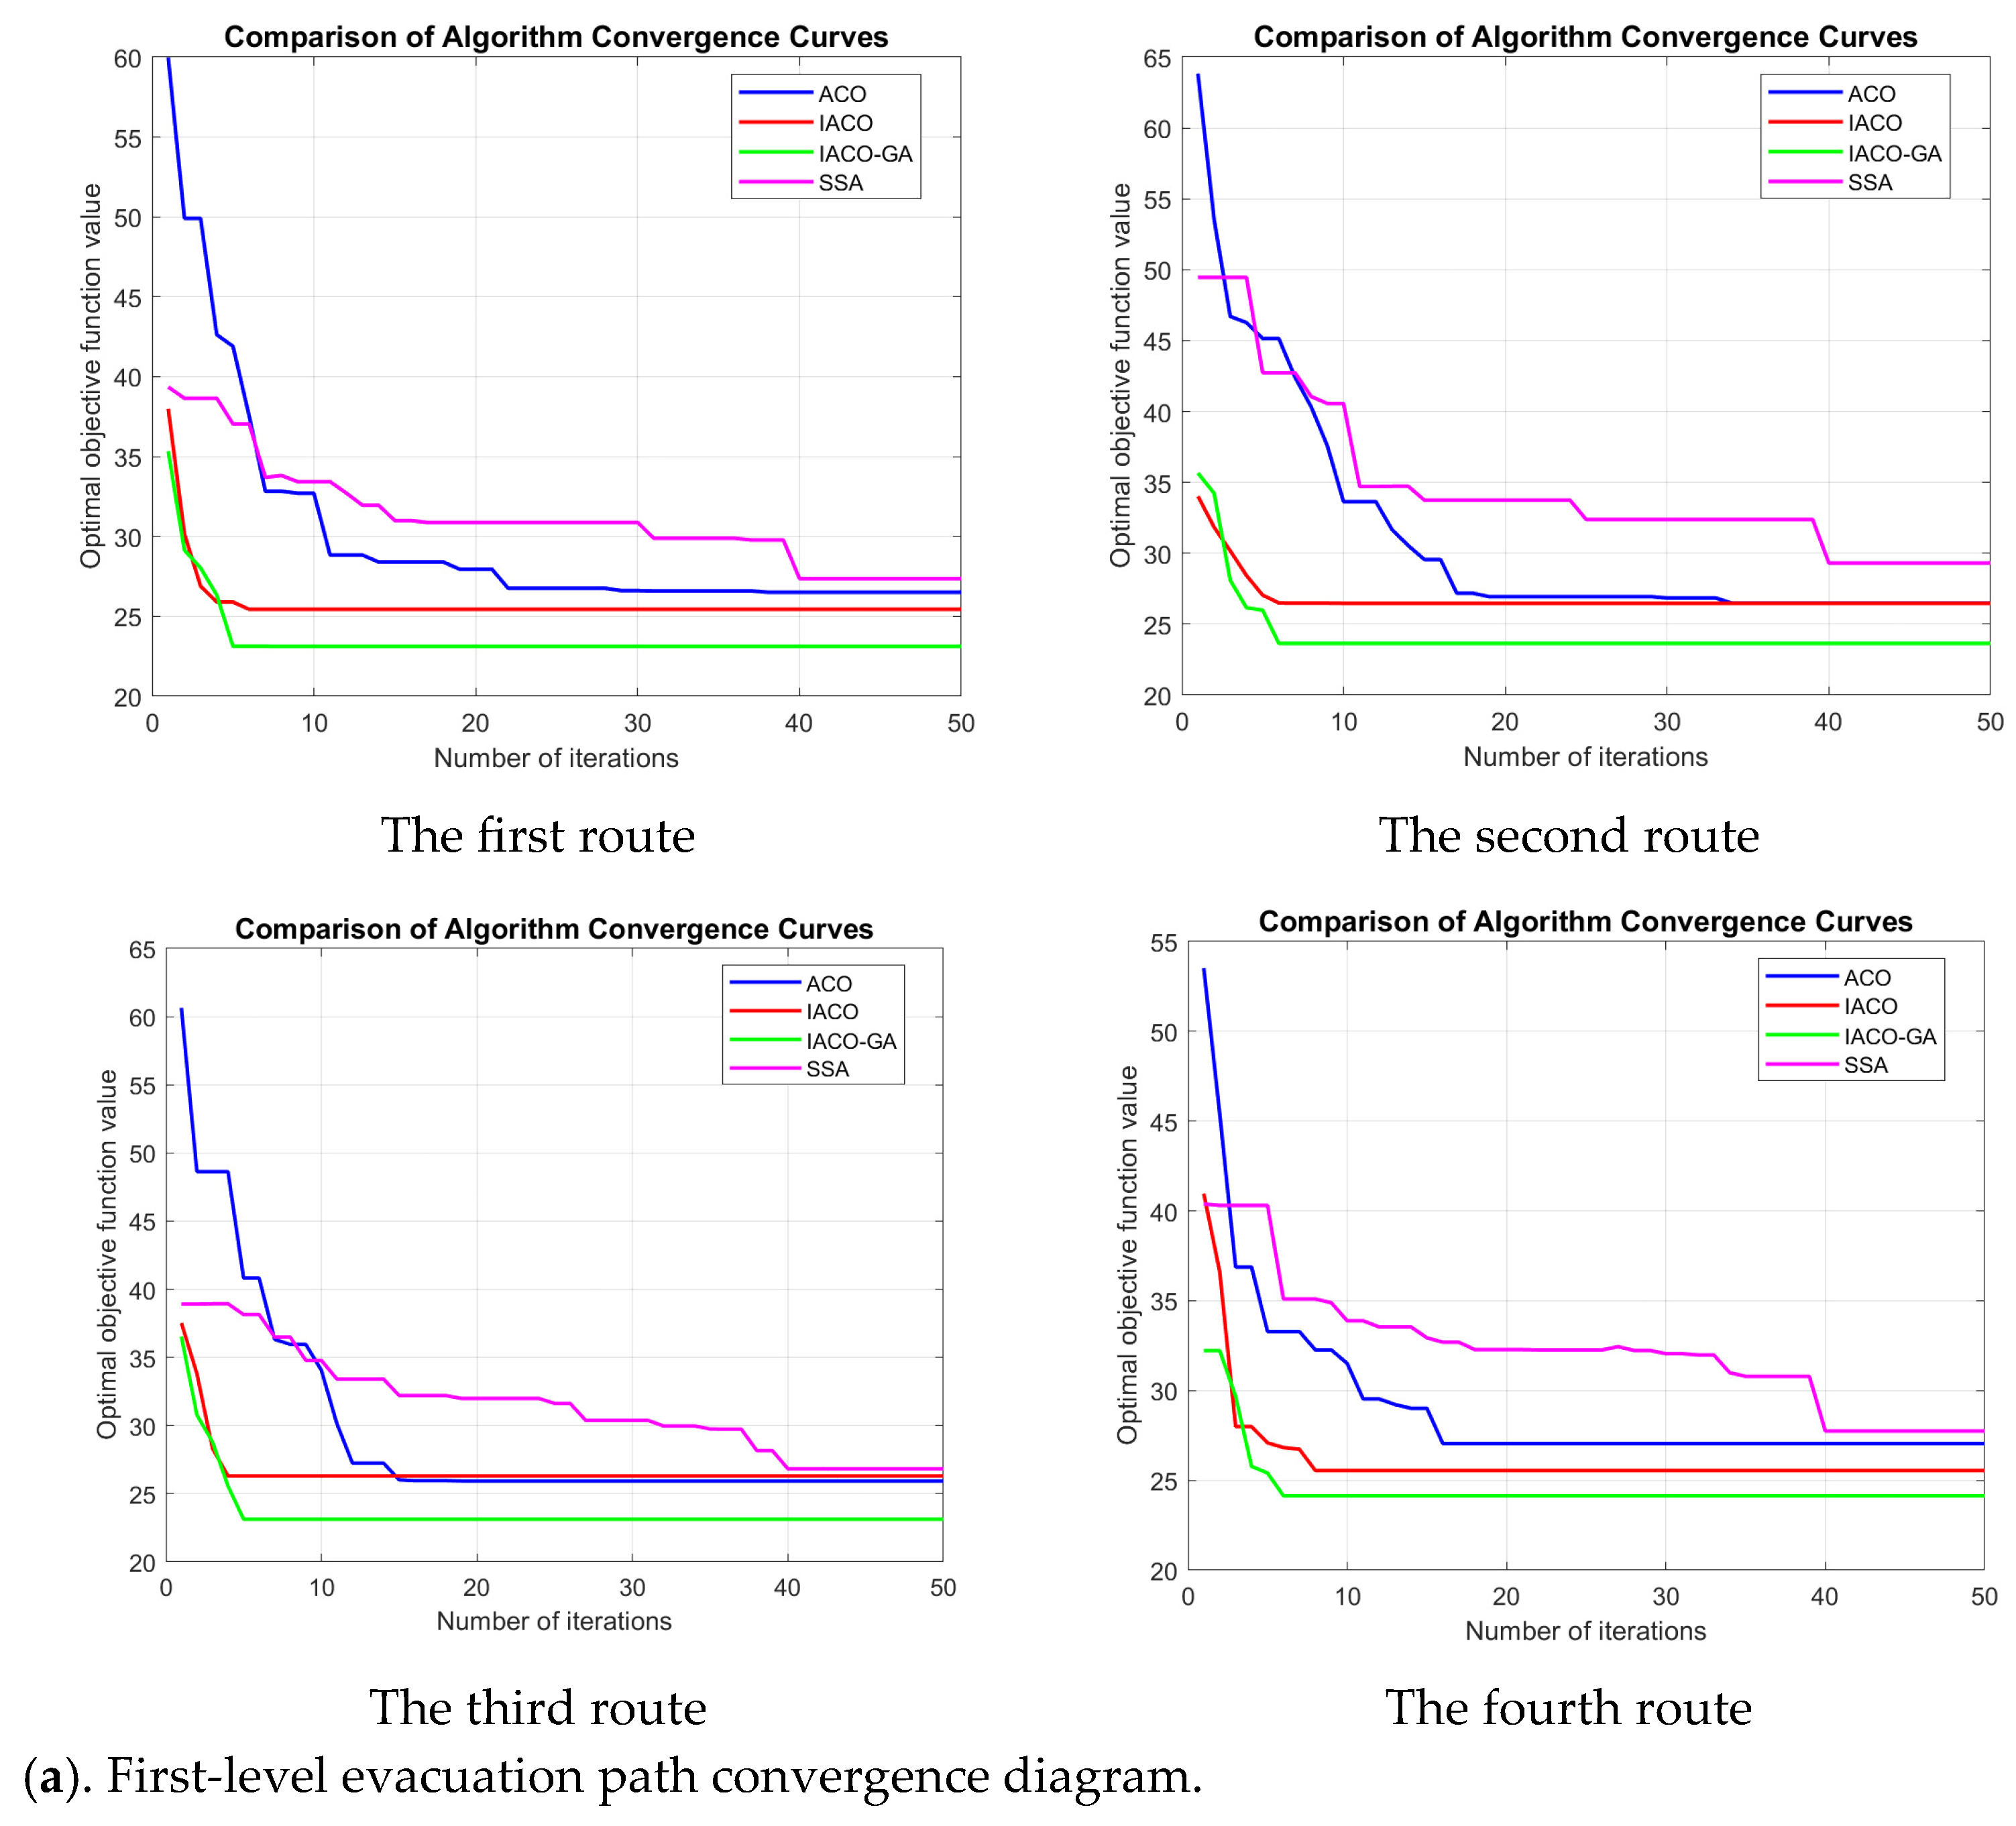
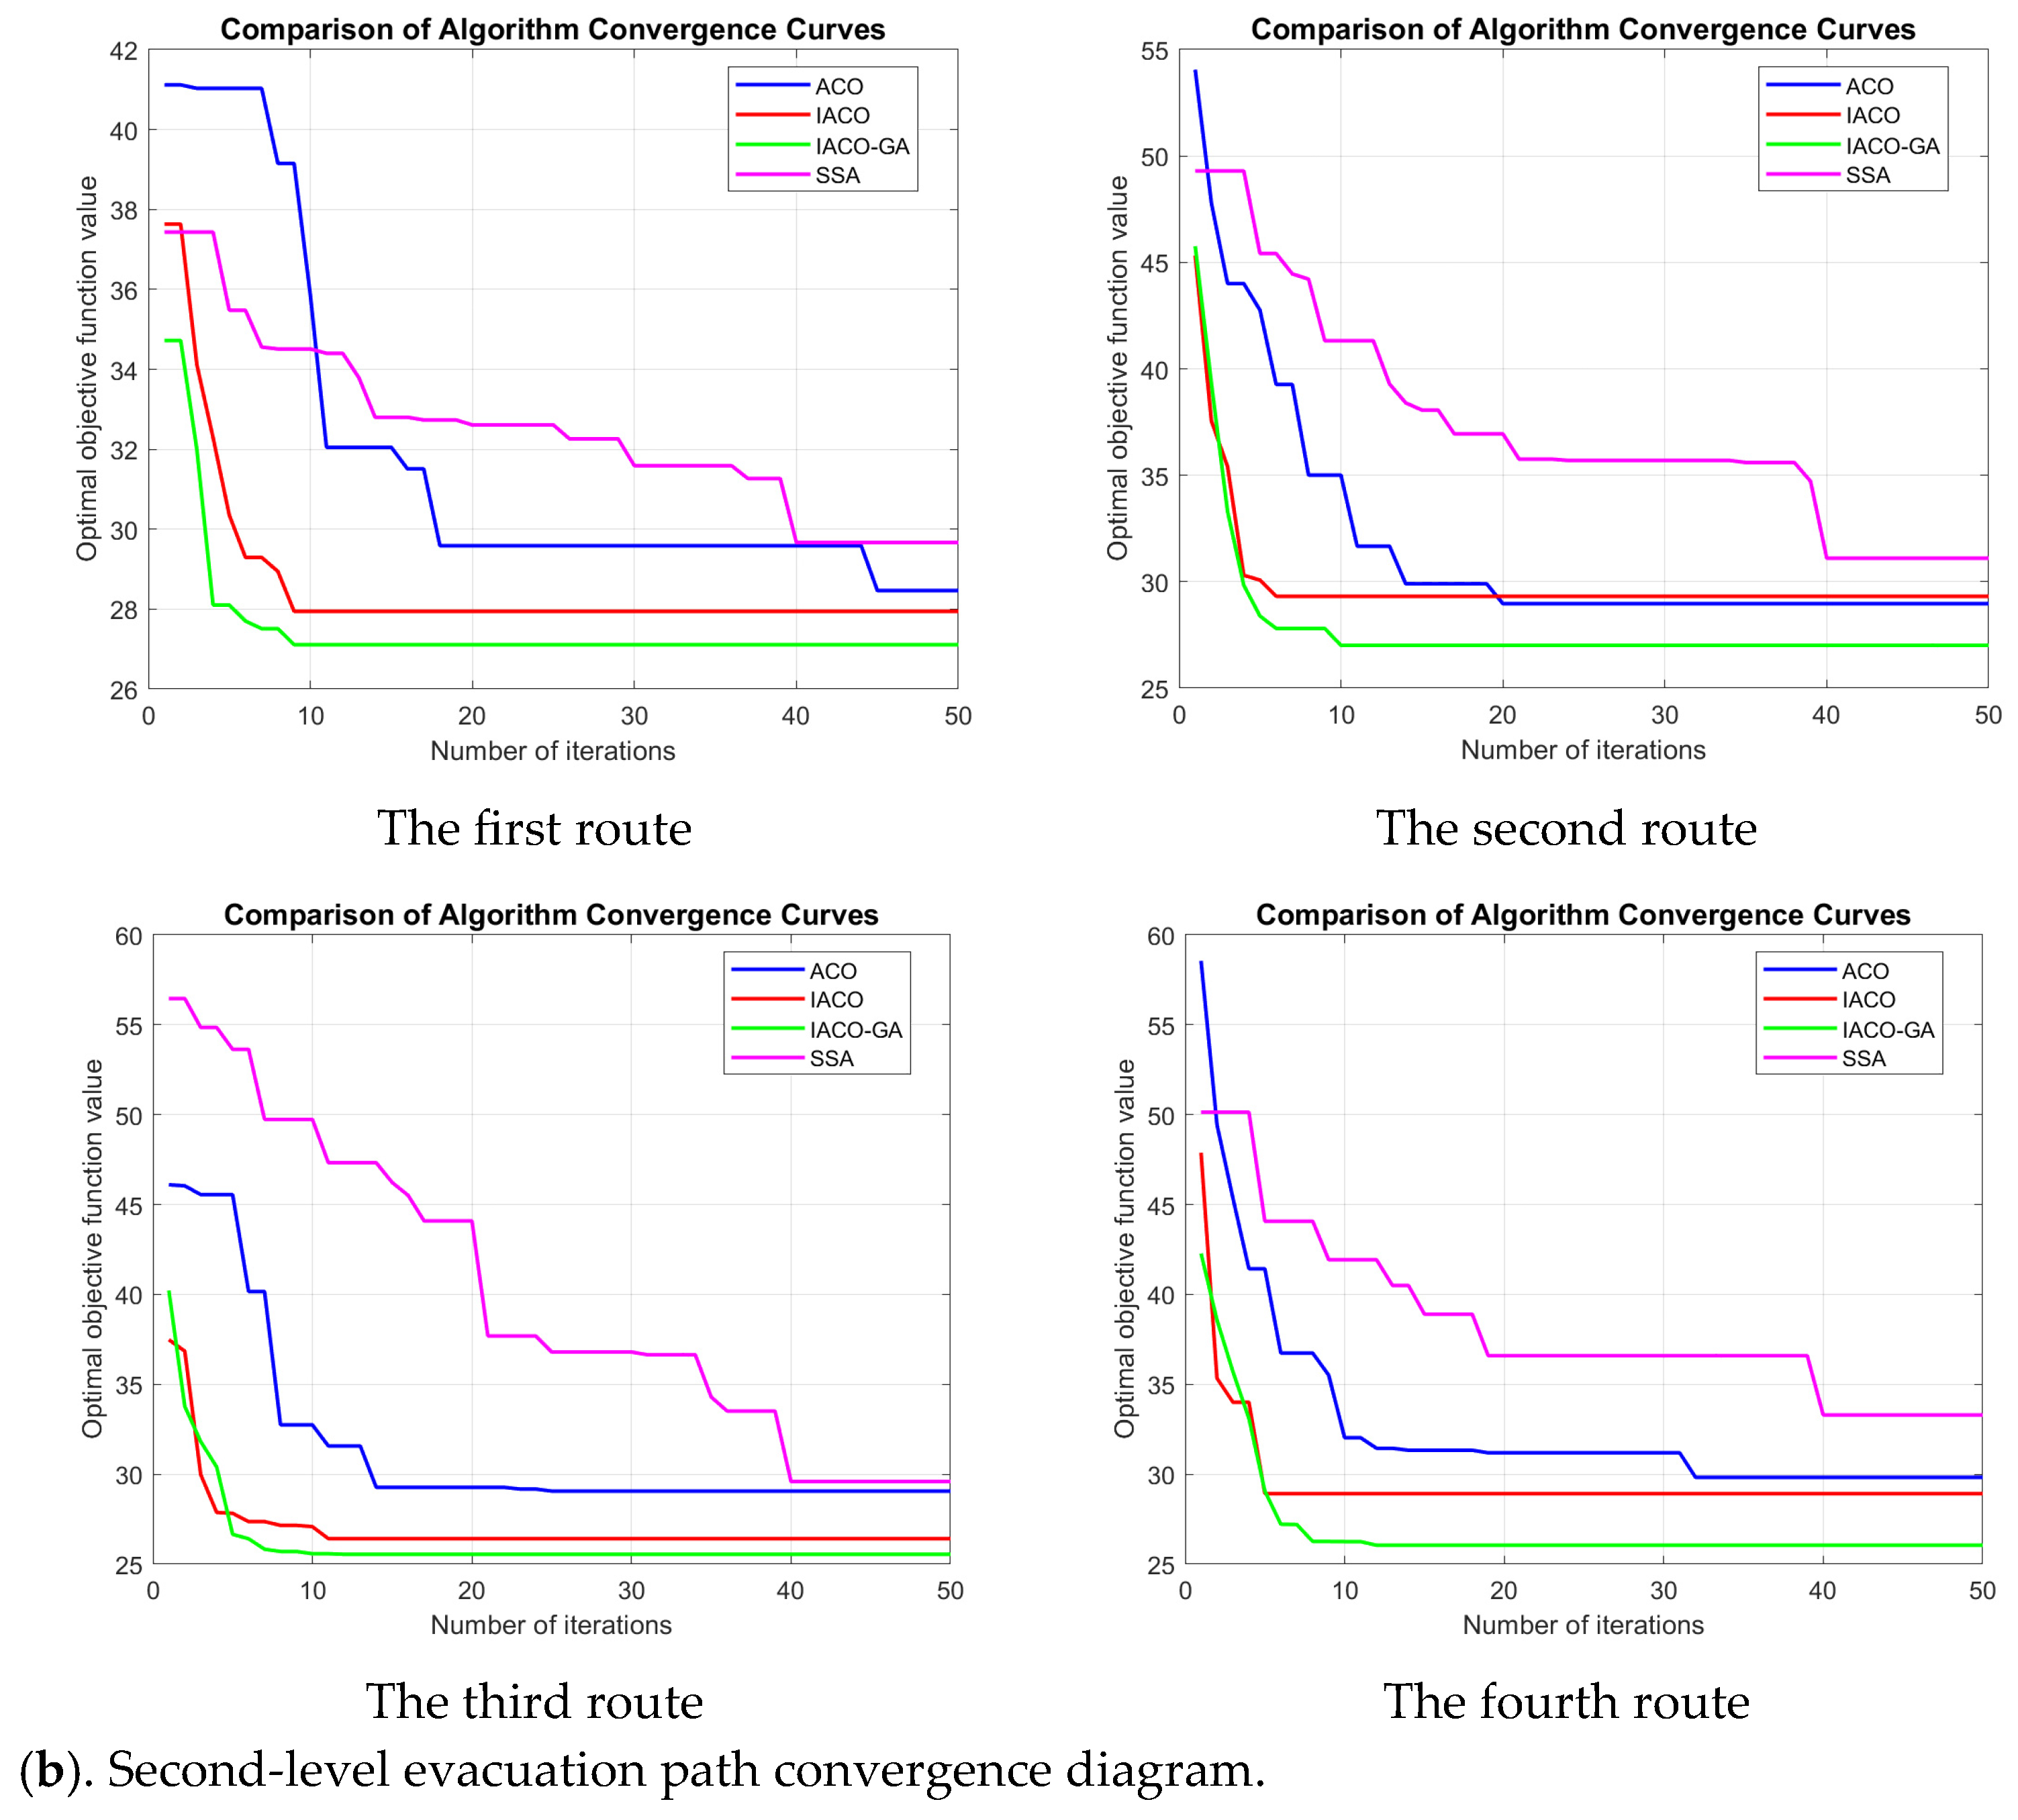
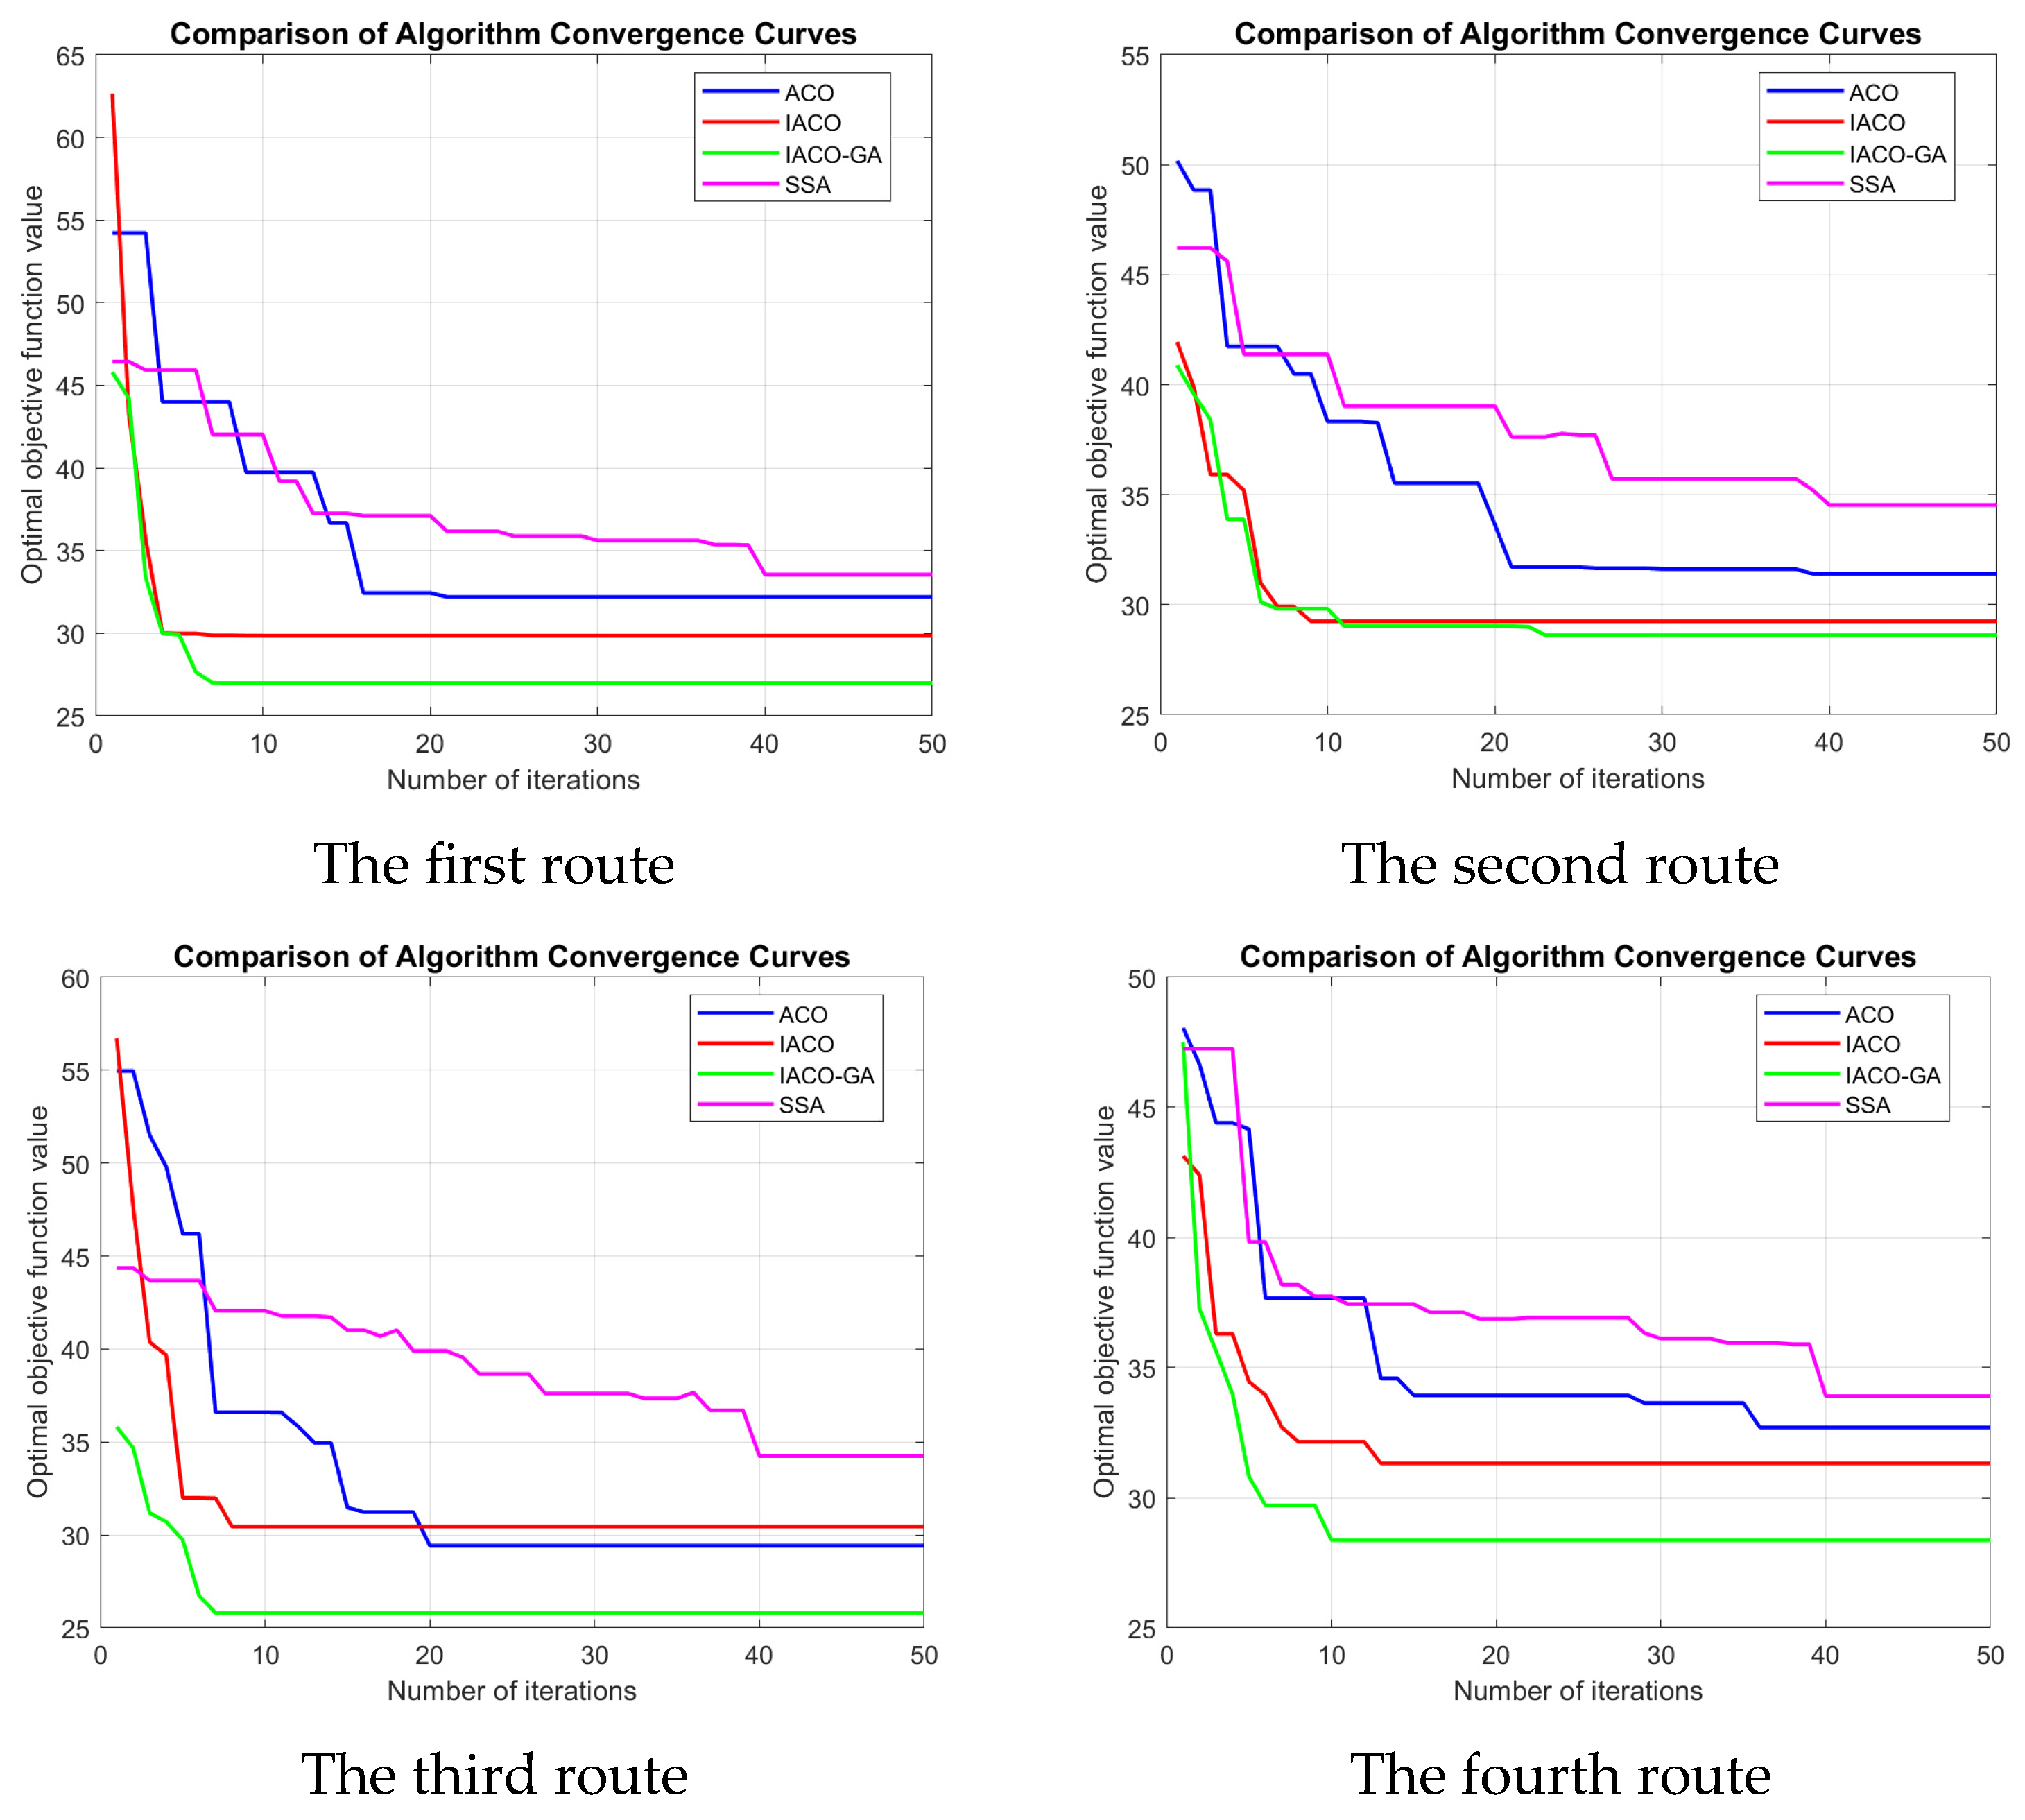
As shown in Table 4 and Table 5, the integrated IACO-GA algorithm outperformed the other three algorithms in finding the optimal path. On the first floor, its optimal path length was reduced by an average of 11.09% compared to ACO and 15.53% compared to SSA. Corresponding reductions on the second floor were 8.99% and 14.30%, respectively. The convergence of these paths for both floors is illustrated in Figure 6.
Figure 6.
Two-layer evacuation path convergence diagram.
Figure 6 illustrates the convergence behavior of the four algorithms, with blue, red, purple, and yellow lines representing ACO, IACO, SSA, and IACO-GA, respectively. The curves show that both ACO and SSA converge relatively slowly, requiring more iterations to stabilize near the optimum. The IACO-GA algorithm demonstrates significant enhancement, finding better solutions faster. While the IACO algorithm converges second-fastest and outperforms the basic ACO, it nevertheless remains slower than IACO-GA in most cases. Simultaneously, the IACO-GA algorithm consistently achieves the lowest final objective function values across all paths, confirming its ability to identify superior solutions for multi-objective path planning. This demonstrates its enhanced global search capability and solution quality.
- (2)
- The initial growth stage of hazard sources
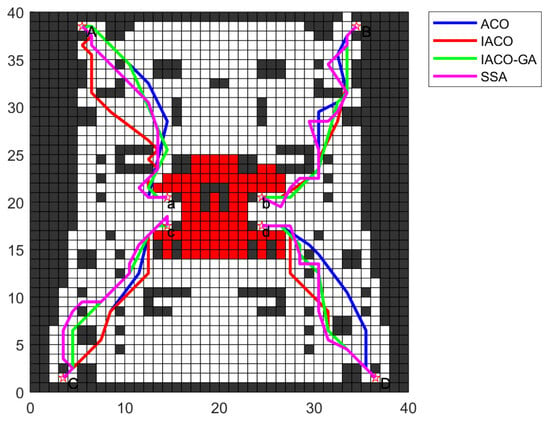
During the initial growth stage of a hazard, certain passageways may become blocked, heightening the danger to evacuating individuals. As people congregate in accessible areas, local crowd density increases significantly. Since the hazard source is located on the second floor, it has a greater impact on that level. Therefore, the following analysis focuses solely on the evacuation procedures for the second floor. The personnel evacuation routes are shown in Figure 7.
Figure 7.
Evacuation routes during the initial growth phase of hazard sources.
As shown in Figure 7, as the hazard source spreads, all three algorithms exhibit changes in evacuation routes compared to those when the hazard source was first detected, with evacuation route lengths increasing across the board. However, the IACO-GA algorithm consistently identifies shorter and smoother routes, enabling faster evacuation times. The corresponding optimal path lengths are listed in Table 4.
As shown in Table 6, the IACO algorithm performs worse than the basic ACO algorithm on the first optimal path; the IACO-GA outperforms the other three algorithms in finding optimal paths. The four-path improvement to the IACO-GA algorithm reduces the average optimal path length by approximately 12.52% compared to the basic ACO algorithm and by approximately 19.32% compared to the SSA. The convergence diagrams for each route are shown in Figure 8.
Table 6.
Comparison of optimal path lengths for personnel evacuation on the second floor.
Figure 8.
Convergence diagram for each evacuation path.
As shown in Figure 8, all four algorithms converge to the optimal objective function value, exhibiting trends similar to the hazard identification phase. Though with uniformly longer paths, this increase in path length presumably results from the spreading hazard, which adds complexity, limits feasible routes, and increases risk, thereby presenting a greater planning challenge. The IACO-GA algorithm demonstrates faster convergence speeds across most routes, indicating that the enhanced ant colony algorithm, through integration with genetic algorithms, has strengthened its global search capabilities and can generate optimal paths more efficiently. Meanwhile, the IACO-GA algorithm consistently outperforms the baseline ACO algorithm, IACO algorithm, and SSA algorithm in terms of final convergence values, indicating that it can identify higher-quality path planning solutions and effectively address complex situations arising from hazardous sources.
- (3)
- Hazard source diffusion stage
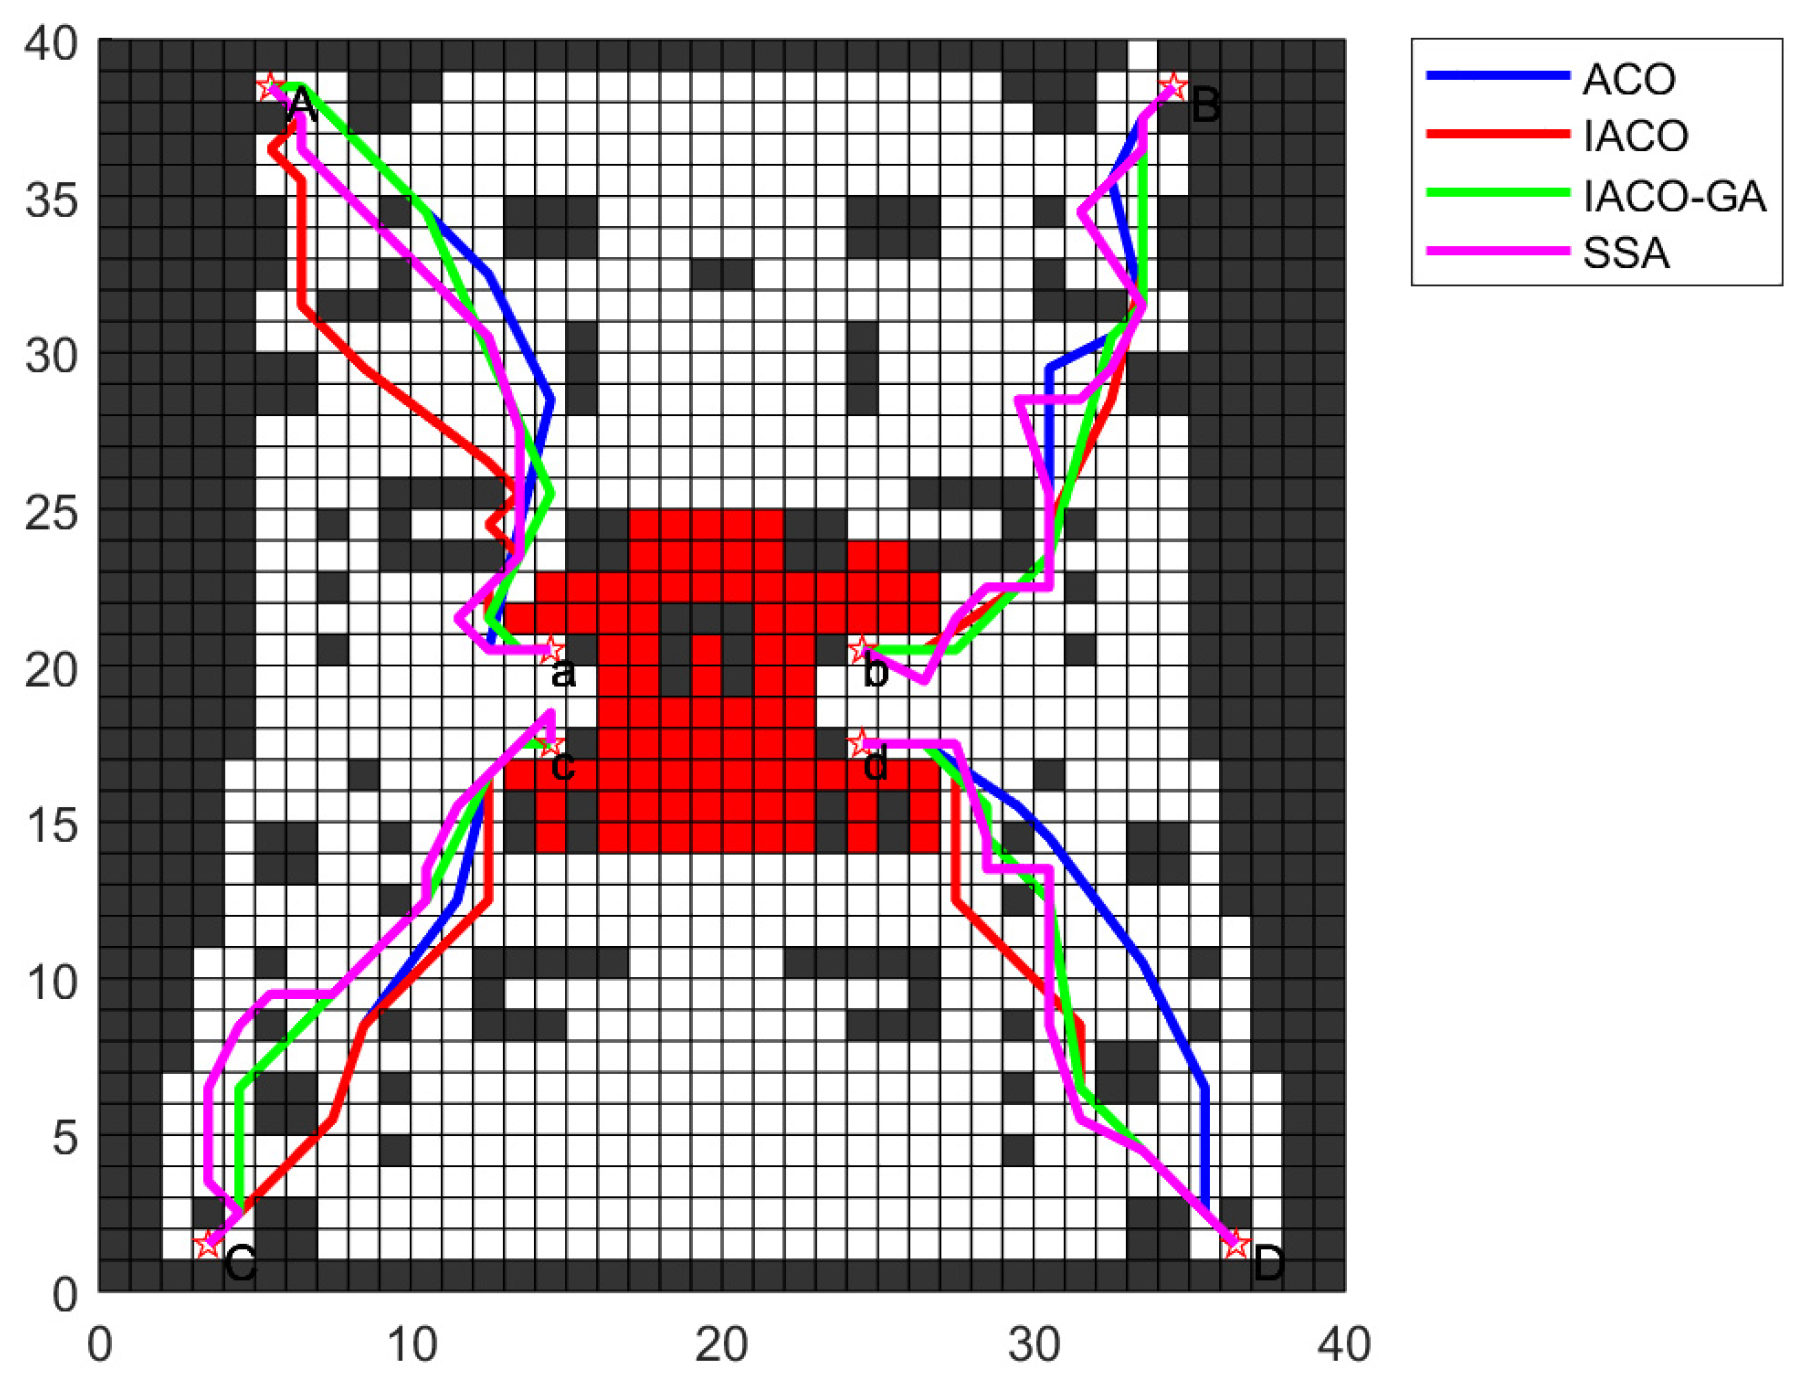
As the hazard source continues to spread, its influence on personnel evacuation intensifies. Assuming that spread blocks the upper-left exit A and lower-right exit D, personnel starting from points A and D must seek alternative exits. The evacuation routes for this phase are illustrated in Figure 9.
Figure 9.
Personnel evacuation routes during hazard source diffusion phase.
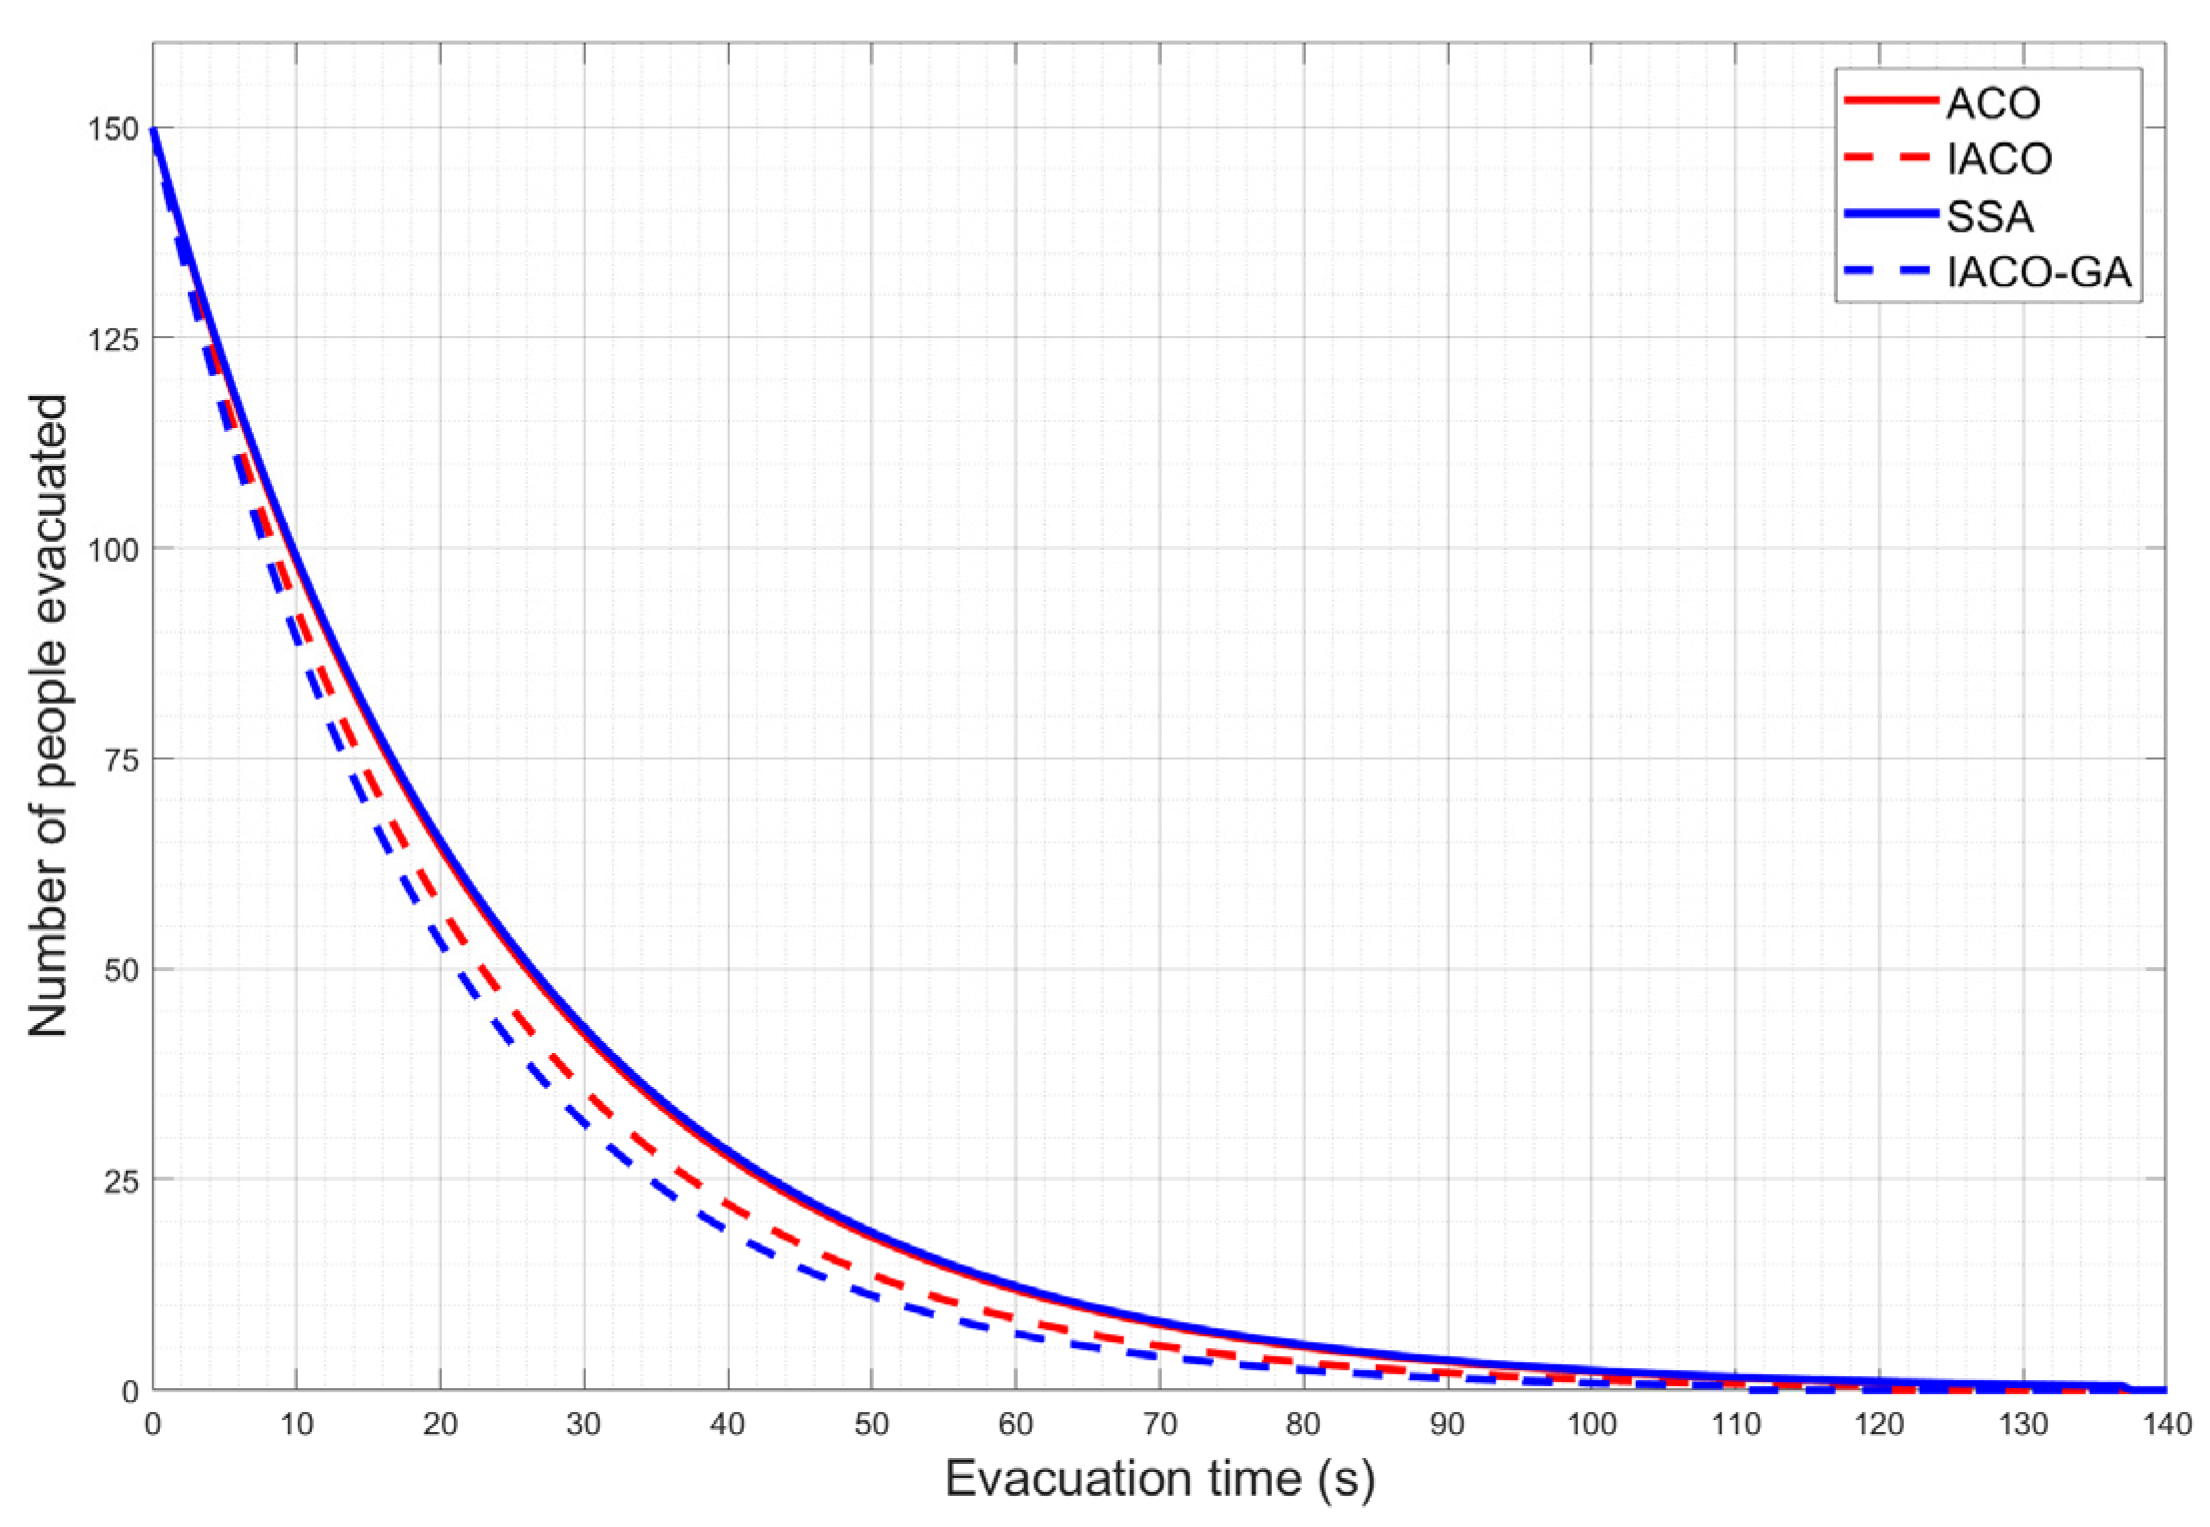
As shown in Figure 9, due to changes in exit availability and the impact of hazard source dispersion on personnel evacuation routes, dynamic adjustments to evacuation paths became necessary. All three strategies rerouted paths to avoid areas affected by hazard sources and unusable exits. The IACO-GA strategy may demonstrate superior adaptability and optimization capabilities in dynamic environments, enabling the provision of safer and more efficient evacuation routes. Evacuation times for different algorithms under identical scenarios are compared in Figure 10.
Figure 10.
Comparison chart of evacuation times for various algorithms.
As shown in Figure 10, under identical crowd size and exit conditions, the evacuation duration for the basic ACO is 135 s, and the evacuation durations were 118 s for the improved ACO, 138 s for the basic SSA, and approximately 110 s for the IACO-GA algorithm. The IACO-GA algorithm reduces the evacuation time by approximately 25% compared to the baseline and achieves the shortest total evacuation time in high-density, multi-exit scenarios.
To validate the effectiveness of the improvement strategy, this paper compares the ACO, IACO, SSA, and IACO-GA algorithms on the same multi-objective path optimization problems. The comparison results are shown in Figure 5.
As shown in Table 7, the IACO-GA algorithm’s dispersion time is 110 s, with a total risk of 0.546 and a panic index of 0.498. The improved fusion algorithm significantly outperforms others in evacuation time, risk, and panic index, making it a more efficient and safer solution for route planning.
Table 7.
Comparison of results from different algorithms.
As shown in Table 8, the widespread dispersion of the hazard has further increased evacuation path lengths compared to earlier phases. With exits A and D blocked, individuals starting at point A now evacuate through exit C, while those from point D use exit B. Consequently, the path lengths of the first and fourth routes have increased significantly. As shown in the table, the IACO-GA algorithm still generates shorter evacuation routes when occupant safety and panic are considered. Shorter paths reduce total evacuation time and increase the likelihood of occupants escaping safely. Among the four routes, the optimal path length of the IACO-GA algorithm was reduced by an average of approximately 17.48% compared to the basic ACO and by an average of 21.14% compared to the SSA.
Table 8.
Comparison of optimal path lengths for personnel evacuation on the second floor.
6. Conclusions
In complex emergency scenarios, the paramount task is to ensure safe and efficient evacuation to minimize casualties and property damage. This necessitates a planning approach that comprehensively optimizes evacuation time, route safety, and crowd panic. Therefore, an emergency evacuation route planning model was developed with three optimization objectives: evacuation time, road segment risk, and crowd panic index. Through multi-objective collaborative optimization, the model identifies a globally optimal evacuation plan to enhance efficiency. To address the limitations of the basic ACO in multi-objective path planning, this paper improves the ACO and integrates it with a GA to solve the model. By introducing multidimensional pheromones and adjusting the heuristic function, the algorithm avoids getting stuck in local optima. Furthermore, global convergence is enhanced by tuning the pheromone volatility factor and pheromone intensity coefficient, along with refining the state transition probability. In evacuation simulation across three typical scenarios, the paths planned by the proposed IACO-GA algorithm demonstrated superior performance in both path length and convergence speed. It thereby provides a stable and efficient planning solution for complex scenarios, effectively enhancing personnel evacuation efficiency.
Author Contributions
Data curation, J.Z. and Y.L. (Ya Liu); methodology, F.W., J.Z., and Y.L. (Yan Li); founding acquisition, F.W.; visualization, J.Z. and Y.L. (Yan Li); validation, F.W. and J.Z.; writing—original draft, F.W. and J.Z.; writing—review and editing, F.W., Y.L. (Yan Li), and Y.L. (Ya Liu).; supervision, F.W. All authors have read and agreed to the published version of the manuscript.
Funding
This research is supported by the Project Supported by the National Natural Science Foundation of China (No. 72274001),the Anhui Provincial Major Research Project in Natural Sciences for Universities (No. 2024AH040027), and National Social Science Fund Key Project (No. 22AJL002) and the Outstanding Research and Innovation Team of Universities in Anhui Province (No. 2022AH010027), the Open Fund Project of Anhui Provincial Key Laboratory at Anhui Agricultural University (No. CS2023-ZD03).
Data Availability Statement
As this work was carried out in an emergency situation, the method of obtaining information was through public data and relevant books of the Chinese government. The data are included in the article and have been explained in the data preparation phase. The original contributions provided in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
No potential conflicts of interest were reported by the authors.
References
- Jiang, H.B.; Kuang, X.H. Improved Snake Optimization and Particle Swarm Fusion Algorithm Based on AUV Global Path Planning. J. Mar. Sci. Eng. 2025, 13, 796. [Google Scholar] [CrossRef] [Scilit]
- Zhou, Q.; Lian, Y.; Wu, J.Y.; Zhu, M.; Wang, H.; Cao, J. An optimized Q-Learning algorithm for mobile robot local path planning. Knowl.-Based Syst. 2024, 286, 111400. [Google Scholar] [CrossRef] [Scilit]
- Hardjomidjojo, H.; Marimin, M.; Suprihatin, S.; Yusianto, R. A synergy of spatial perspective based non-numeric ME-MCDM and modified Dijkstra algorithm for optimal distribution route selection. Int. J. Inf. Decis. Sci. 2022, 14, 371–398. [Google Scholar] [CrossRef] [Scilit]
- Singh, R.K.; Nagla, K.S. Enhanced A* Algorithm for the Time Efficient Navigation of Unmanned Vehicle by Reducing the Uncertainty in Path Length Optimization. MAPAN 2023, 38, 317–335. [Google Scholar] [CrossRef] [Scilit]
- Kim, M.; Lee, M.; Kim, B.; Cha, M. Development of Local Path Planning Using Selective Model Predictive Control, Potential Fields, and Particle Swarm Optimization. Robotics 2024, 13, 46. [Google Scholar] [CrossRef] [Scilit]
- Luo, Y.; Tan, J.X.; Han, Y.H. Global path planning method based on improved genetic algorithm. Clust. Comput. 2026, 29, 76. [Google Scholar] [CrossRef] [Scilit]
- Davoud, S.; Houman, M. Optimization of multi objective vehicle routing problem using a new hybrid algorithm based on particle swarm optimization and artificial bee colony algorithm considering Precedence constraints. Alex. Eng. J. 2017, 57, 2225–2239. [Google Scholar]
- Zhang, S.Y.; Guo, B.L.; Chen, L.Z.; Liu, H.X. Path Planning of intelligent Fire Evacuation Map Based on Bidirectional Ant Colony Algorithm. Comput. Eng. Appl. 2021, 57, 259–266. [Google Scholar]
- Wang, F.Y.; Xie, H.X.; Lin, Z.G.; Wang, J. Multi-objective Optimization Model and Adaptive Quantum Ant Colony Algorithm for Emergency Evacuation of High-speed Railway Stations under emergencies. Chin. J. Manag. Sci. 2024, 32, 188–197. [Google Scholar]
- Damos, M.A.; Xu, W.; Zhu, J.; Ahmed, A.; Khader, A. An Efficient Tourism Path Approach Based on Improved Ant Colony Optimization in Hilly Areas. ISPRS Int. J. Geo-Inf. 2025, 14, 34. [Google Scholar] [CrossRef] [Scilit]
- Katada, Y.; Kato, T.; Nakajima, N. Route planning of an unmanned aerial vehicle using ant colony optimization for environment including a no-fly zone and obstacles. Artif. Life Robot. 2025, 1–11, prepublish. [Google Scholar] [CrossRef] [Scilit]
- Yamamoto, K.; Li, X.M.; Yue, X.G. Safety Evaluation of Evacuation Routes in Central Tokyo Assuming a Large-Scale Evacuation in Case of Earthquake Disasters. J. Risk Financ. Manag. 2017, 10, 14. [Google Scholar] [CrossRef] [Scilit]
- Ntakolia, C.; Lyridis, D.V. A comparative study on Ant Colony Optimization algorithm approaches for solving multi-objective path planning problems in case of unmanned surface vehicles. Ocean Eng. 2022, 255, 111418. [Google Scholar] [CrossRef] [Scilit]
- Liu, J.J.; Qian, Y.H.; Zhang, W.Z.; Ji, M.; Xv, Q.; Song, H. High-safety path optimization for mobile robots using an improved ant colony algorithm with integrated repulsive field rules. Robot. Auton. Syst. 2025, 190, 104998. [Google Scholar] [CrossRef] [Scilit]
- Aziz, M.; Wang, T.X. Examining the evacuation routes of the sister village program by using the ant colony optimization algorithm. Open Geosci. 2023, 15, 20220512. [Google Scholar] [CrossRef] [Scilit]
- Bassolillo, R.S.; D’Amato, E.; Notaro, I.; D’agati, L.; Merlino, G.; Tricomi, G. Bridging ACO-Based Drone Logistics and Computing Continuum for Enhanced Smart City Applications. Drones 2025, 9, 368. [Google Scholar] [CrossRef] [Scilit]
- Wang, F.Y.; Huang, A.L.; Sun, H.; Zio, E. Dynamic ensemble model incorporating deep reinforcement learning for earthquake casualty prediction. Reliab. Eng. Syst. Saf. 2026, 267, 111955. [Google Scholar] [CrossRef] [Scilit]
- Lee, S.; Joo, H.; Kim, K.; Kim, H. Rolling-horizon genetic algorithm for adaptive path planning in hazardous environments. Comput. Electr. Eng. 2026, 129, 110820. [Google Scholar] [CrossRef] [Scilit]
- Marseglia, L.; Vale, A.; Di Gironimo, G. Genetic Algorithm-Based Optimization of Velocity Profiles for Multi-Robot Collision Avoidance. Machines 2025, 13, 1036. [Google Scholar] [CrossRef] [Scilit]
- Kordkheili, M.B.; Sahraeian, R.; Costa, Y. Improved Benders decomposition for home healthcare vehicle and drone routing problem in two-echelon supply chains. Comput. Oper. Res. 2026, 186, 107306. [Google Scholar] [CrossRef] [Scilit]
- Gasteratos, G.; Karydis, I. Strategic Launch Pad Positioning: Optimizing Drone Path Planning Through Genetic Algorithms. Information 2025, 16, 897. [Google Scholar] [CrossRef] [Scilit]
- Maktabifard, A.; Földes, D. Cooperative driving route planning based on asymmetric multi-agent path planning problem with limited service area constraints. Appl. Soft Comput. 2025, 185, 113959. [Google Scholar] [CrossRef] [Scilit]
- Alzubairi, S.; Petunin, A.; Msallam, M.M.; Alwan, H.L. Multi-Target Robot Path Planning Using Enhanced Genetic Algorithms and Probabilistic Roadmaps. Proc. Eng. Technol. Innov. 2025, 31, 29–44. [Google Scholar] [CrossRef] [Scilit]
- Wu, M.; Su, M.L.E.; Yeong, F.C.; Dong, B.; Holderbaum, W.; Yang, C. A hybrid path planning algorithm combining A* and improved ant colony optimization with dynamic window approach for enhancing energy efficiency in warehouse environments. Peer J. Comput. Sci. 2024, 10, e2629. [Google Scholar] [CrossRef] [Scilit]
- Lan, Y.; Luo, L.; Su, S.; Li, S.; Zhang, W. Path Optimization of Drone-Truck Collaborative Delivery Based on Ant Colony and A* Algorithm. J. Phys. Conf. Ser. 2025, 3108, 012017. [Google Scholar] [CrossRef] [Scilit]
- Châari, I.; Koubâa, A.; Trigui, S.; Bennaceur, H.; Ammar, A.; Al-Shalfan, K. SmartPATH: An Efficient Hybrid ACO-GA Algorithm for Solving the Global Path Planning Problem of Mobile Robots. Int. J. Adv. Robot. Syst. 2014, 11, 622–625. [Google Scholar] [CrossRef] [Scilit]
- Raei, B.; Sen, A.; Kinateder, M.; Bénichou, N.; Wang, X. Optimizing evacuation routes for human mobility during wildfires: A case study of the 2023 McDougall Creek Wildfire. Transp. Res. Part D 2026, 153, 105216. [Google Scholar] [CrossRef] [Scilit]
- Amr, M.; Bahgat, A.; Rashad, H.; Ibrahim, A.; Youssef, A. Optimizing Navigation in Mobile Robots: Modified Particle Swarm Optimization and Genetic Algorithms for Effective Path Planning. Algorithms 2025, 18, 719. [Google Scholar] [CrossRef] [Scilit]
- Song, Y.L.; Yan, X.D. A Method for Formulizing Disaster Evacuation Demand Curves Based on SI Model. Int. J. Environ. Res. Public Health 2016, 13, 986. [Google Scholar] [CrossRef] [Scilit]
- Wu, X.J.; Wang, W.L.; Hu, Z.H. Study on Emotion Contagion Model and Intervention Strategies of Panic in Subway Stations Under Emergence. Comput. Eng. Appl. 2020, 56, 265–272. [Google Scholar]
- Xiao, Y.; Zhou, L.H. Chaotie dynamies analysis of a periodically perturbed SIRS epidemic model. J. Northeast Norm. Univ. (Nat. Sci. Ed.) 2025, 57, 37–44. [Google Scholar]
- Zhang, H.B.; Huang, S.X.; Liu, F.; Liu, W.J.; Zhou, H. Optimization of Evacuation Routes Based on Genetic Algorithm. Ind. Saf. Environ. Prot. 2020, 46, 24–28. [Google Scholar]
- Liang, J.T.; Wang, H.Q. Study on Building Fire Evacuation Path Planning Based on Improved Ant Colony Algorithm. J. Syst. Simul. 2022, 34, 1044–1053. [Google Scholar]
- Zhang, M.; Hao, P. 2D and 3D path planning for mobile robots based on improved SSA algorithm. Int. J. Intell. Robot. Appl. 2024, 9, 176–188. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.