


Abstract
With the urgent need of the industry and the continuous development of artificial intelligence, research into intelligent excavators has achieved certain progress. However, intelligent excavators often face strong vibrations, dense dust, and complex objectives. These have brought severe challenges to environmental perception, and are important research difficulties that must be overcome in realizing the practical engineering applications of intelligent excavators. Many researchers have studied these problems in reducing vibration and dust noise for light detection and ranging (LiDAR) scanners, multi-sensor information fusion, and the segmentation and recognition of 3D scenes. This paper reviews the research status of these key technologies and discusses their development trends.
1. Introduction
Excavators are widely used in engineering construction, emergency rescue, energy extraction, and other important fields, which is a powerful guarantee to promote the development of the national economy. They play an important role in improving construction efficiency, reducing labor intensity, guaranteeing project quality, and reducing operational risks [1,2]. In various construction sites, excavators perform 65% to 70% of earthmoving work. Large excavation is mainly used in mining, large-scale infrastructure projects, and other fields. Medium excavation is mainly used in real estate, urban construction, transportation construction, and other fields. Small excavation is mainly used in small earth and rock works, pavement repair, and other fields. There are requirements for construction accuracy, efficiency, energy consumption, and other aspects of continuous improvement, as well as the serious challenges posed by the special working environment [3,4,5]. Traditional driver-operated excavators can no longer meet the requirements of projects, and there are mainly the following problems, as shown in Figure 1.
Figure 1.
Common problems of traditional excavators in extreme working conditions.
- Low construction accuracy, low work efficiency, and high energy consumption. Conventional excavators are affected by human factors, and the accuracy of operation cannot be guaranteed. The low full bucket rate reduces the mining efficiency and energy utilization rate and requires a lot of energy consumption.
- Severe challenges are brought by special working environments. In the process of underwater operation, space development, emergency rescue, etc., the traditional excavator is restricted by the uncertainty and safety of the working environment, so it is difficult to realize normal operation.
- Frequent failures and poor safety. Some operators are accustomed to digging deeply with brute force, resulting in strong impact loads on the bucket. The whole machine vibrates violently, and accidents such as broken shafts and pins and overturning of the lifting arm are likely to happen. When the bucket is loading, collisions happen easily due to human error or limited vision.
To address the challenges faced by traditional excavators, advanced technologies such as artificial intelligence, robotics, and automatic control are applied to upgrade conventional excavators. The goal is to develop an intelligent excavator capable of autonomous operation. This system integrates functions such as environmental perception, excavation trajectory planning, and path planning. Such an intelligent excavator has significant practical implications, offering considerable benefits both economically and socially.
In addition to the basic system of the traditional excavator, the intelligent excavator also has an environmental perception system, pose detection system, walking path planning system, excavation trajectory planning system, and intelligent control system, as shown in Figure 2.
Figure 2.
Main systems of intelligent excavators.
The environmental perception system uses visual sensors such as cameras and light detection and ranging scanners to perceive the mining target, loading vehicle, road conditions, and other working environment information, and then synchronizes and fuses the relevant information, and uses relevant algorithms to model, identify and segment the working target; the position and attitude detection system uses Global Positioning System (GPS), inertial navigation module, and other sensors to measure the position and attitude information of excavator car body and bucket in real time; the walking path planning system can plan the walking path of the excavator chassis in real time according to the road condition information and the excavator position information to ensure efficient, stable and safe walking. The excavation and loading trajectory planning system performs path planning for both excavation and loading tasks based on environmental perception data, including excavation and loading target information, as well as bucket pose data. The intelligent control system receives the relevant information of other systems in real time, and adopts the robust adaptive control algorithm to control the intelligent excavator. Among them, the environmental perception system is the premise and basis of the walking path planning system, the excavation and loading trajectory planning system, and the intelligent control system. Its performance directly determines the realization level of the intelligent excavator.
1.1. Literature Review Methodology
This survey reviews the latest research progress of intelligent excavators and key environmental perception technologies for intelligent excavators at home and abroad. After screening and analysis, a total of 126 published papers were selected. As can be seen from the literature in the list, research on intelligent excavator technology has received more and more attention. In this survey, we conducted a systematic literature search through multiple academic databases, mainly using platforms including Google Scholar, IEEE Xplore, and Web of Science. To accurately locate the research literature in the field of intelligent excavators, we used a search method of filtering keywords, such as “intelligent excavators”, “environmental perception”, “Light Detection and Ranging (LiDAR)”, “vibration reduction technology”, “dust reduction technology”, “multi-sensor information fusion”, “segmentation and recognition of 3D scenes”, “visual perception”, “deep learning”, “Robot perception”, etc. At the same time, to understand the development of key environmental perception technologies for intelligent excavators, we screened the literature published between 1999 and 2024 and focused on the research results of the last five years. Subsequently, the screening results were filtered based on relevance as well as references. Finally, based on the research topics and technical content, we categorized all the selected literature into several main categories. This classification allows for a systematic summary of the development trends in the environmental perception technologies for intelligent excavators.
1.2. Research Status of Intelligent Excavators
Since intelligent excavators have the characteristics of high scientific and technological content, clear application objects, and good market prospects, since Europe and the United States began to develop the first intelligent excavator in 1995, research on intelligent excavators has been widely valued by many universities and scientific research institutions at home and abroad. After more than 20 years of development, certain research results have been achieved. The intelligent excavator developed by the University of Tsukuba in Japan uses a variety of sensors, as shown in Figure 3.
Figure 3.
Various sensors on intelligent excavators.
As can be seen from the analysis of Table 1, the research of intelligent excavators has made certain progress, and rich research results have been formed in trajectory planning, obstacle avoidance, excavation trajectory planning, path planning, automatic control, and other aspects. Most of these research results are oriented to specific ideal working conditions or laboratory environments. However, intelligent excavator operation is often faced with strong vibrations, high dust levels, and complex and dynamic working object structure, which brings severe challenges to the intelligent excavator operating environmental perception.
Table 1.
Research status of intelligent excavators at home and abroad.
- The operation of intelligent excavators is often accompanied by strong vibrations, which will cause linear deviation and attitude angle change of the light detection and ranging scanner, thus affecting the detection accuracy of the LiDAR scanner. In addition, strong vibrations will cause fatigue and wear of the precision components inside the light detection and ranging scanner, affect the service life of the equipment, and even cause damage to the equipment. Therefore, it is necessary to study the vibration characteristics of the excavator, design a reasonable vibration-damping platform, and measure the light detection and ranging scanner displacement and attitude data caused by vibration, as well as modify the data through registration, filtering, and other algorithms as far as possible to eliminate the impact of vibration on the measurement accuracy of the light detection and ranging scanner.
- The intelligent excavator will produce a large amount of dust during the excavation and loading process. When the dust concentration in the air reaches a certain degree, it will seriously affect the effective measurement accuracy of the Light Detection and Ranging scanner on the working environment and the working target, and more serious cases will appear blocking phenomenon. To study the acquisition and noise reduction processing of three-dimensional point cloud data of excavator operating environment under dusty conditions, and to reduce the influence of dust on LiDAR measurement data. It is of great significance to improve the sensing ability of the operating environment of intelligent excavators.
- The excavation targets and loading vehicles faced by intelligent excavators in the construction process are often complex in structure, with diverse details such as shape, color, texture, etc., and outdoor operations susceptible to the impact of light, weather, etc. These will seriously affect the environmental perception effect of intelligent excavators. Multi-sensor information fusion technology is of great significance in improving the working environmental perception ability of intelligent excavators under complex working conditions. In environmental perception tasks, a single sensor faces many shortcomings, and LiDAR can obtain accurate position information. But the collected point cloud data lack important information such as color and texture, and the point cloud data are relatively sparse. In complex operating environments, this will affect the ability to identify fine target features. The camera can acquire rich color and texture information, and the resolution of the image data is relatively high. However, since the camera is a passive measurement sensor, it is less robust, seriously affected by the environment, and unable to directly obtain depth information. Compared with the traditional single sensor, the multi-sensor information fusion technology can obtain more comprehensive, accurate, and robust operating environment information. Therefore, it plays a crucial role in improving the operating environmental perception ability of intelligent excavators under complex conditions.
- The segmentation and recognition of the three-dimensional operation scene of the intelligent excavator (as shown in Figure 4) is the basis for realizing the intelligence of the excavator. Since the three-dimensional point cloud can accurately record the position and geometric information of the measured target, it has advantages that cannot be compared with two-dimensional (2D) images. This important information is the basis for intelligent excavators to carry out tasks such as path planning and trajectory planning, so the perception data of the operating scene is mainly based on the three-dimensional point cloud. Compared with two-dimensional images, the data structure of a three-dimensional point cloud is more complex and disordered, and the intelligent excavator operation scene is complex and dynamic, which brings great challenges to segmentation and recognition. Therefore, the research of three-dimensional operation scene segmentation and recognition technology is of great significance to the realization of excavator intelligence.Figure 4. Segmentation and recognition of the excavator working targets.
In summary, a review and analysis of the current status of key environmental perception technologies, such as LiDAR vibration reduction, LiDAR dust noise reduction, multi-sensor information fusion, and segmentation and recognition of 3D operating scenes, is provided both domestically and internationally. Their research priorities and technological development trends are discussed, which will help improve the environmental perception ability of intelligent excavators. It is of great practical significance to improve the practical application level of intelligent excavators.
2. Research Status of Key Technology for Environmental Perception of Intelligent Excavators
Intelligent excavator operating environmental perception refers to the process of intelligent excavators using the sensor carried by itself to obtain the excavator operating environment information, and to process, interpret, and assign meaning to the information. The sensors carried by the intelligent excavator itself include LiDAR, cameras, a GPS global positioning system, an inertial navigation system and so on. Operating environmental perception is the premise of realizing automatic digging, loading, path planning, control, and other functions, and is the key to realizing an intelligent excavator. However, the complex working conditions faced by the excavator bring severe challenges to the environmental perception, and it is urgently needed to conduct an in-depth discussion on the key technologies of intelligent excavator environmental perception facing complex working conditions. As shown in Figure 5, this paper mainly researches key technologies such as LiDAR vibration reduction, LiDAR dust noise reduction, multi-sensor information fusion, and intelligent segmentation and recognition of excavator operating targets under complex working conditions of intelligent excavators.
Figure 5.
Key technologies of environmental perception under complex working conditions.
2.1. Research Status of LiDAR Vibration Reduction Technology
To collect excavator vibration data in real time, Chen et al. [23] designed an excavator vibration monitoring recorder with an STM32F103 microcontroller as the core. Huang et al. [24] used wavelet packet band energy decomposition and Hilbert–Huang transform, respectively, to study the noise reduction methods of vibration signals in the process of excavator shoveling. The research shows that the reconstructed vibration signals based on the Hilbert–Huang transform can better reflect the essential characteristics of real vibration signals. Zhou et al. [25] established the finite element model of the excavator cab mechanism, conducted modal analysis on the noise and vibration characteristics of the excavator cab, and optimized the cab structure based on the analysis results, effectively reducing the vibration and noise. Zhang et al. [26] studied the vibration characteristics of the lifting mechanism of excavators and obtained the reasonable vibration range of the lifting mechanism through experimental analysis. The above studies are all aimed at the vibration analysis of the excavator itself. However, compared with traditional excavators, intelligent excavators need to use LiDAR for environmental perception, and vibration has a greater impact on environmental perception accuracy. Therefore, the research of LiDAR vibration reduction technology is of great importance to intelligent excavators. At present, research on the LiDAR vibration reduction technology of intelligent excavators is still limited. However, there is a solid research foundation in related fields such as unmanned and aerospace vehicles, which can play a certain role in the research of LiDAR vibration reduction for intelligent excavators. These studies are mainly divided into two types.
- In terms of software, vibration theory analysis or simulation studies of the LiDAR detection process under vibration conditions are conducted. A response model is established between the LiDAR measurement data and vibrations, enabling compensation and correction of measurement data affected by vibration.
- In terms of hardware, the main vibration parameters, such as amplitude and frequency, are measured through experiments, and the vibration patterns are analyzed. Then, a vibration-damping platform is designed, and an optimal installation position is selected, effectively reducing the impact of vibration on the LiDAR.
In terms of software, Ma et al. [27] proposed a simulation method to evaluate the impact of vibration error on the scanning accuracy of LiDAR. The research shows that the vibration of LiDAR platforms seriously reduces the position accuracy of the point cloud, and the position accuracy error caused by vibration is relatively complex, and cannot be fitted with a simple polynomial function. Ma et al. [28] proposed a method based on trajectory dual-detector interferometry to estimate and compensate LiDAR phase errors caused by platform vibration. Hu et al. [29] proposed a new LiDAR vibration estimation method to solve the problem of large vibration estimation error under the conditions of wide azimuth beam and low SNR. Cui et al. [30] analyzed the working principle and corresponding vibration of vehicle-mounted three-dimensional scanning LiDAR to solve the problem of ranging accuracy error caused by road impact and vibration, established a mathematical model between shock and vibration excitation and circuit vibration and noise response, and proposed a vibration and noise elimination method based on wavelet analysis. Su et al. [31] studied the imaging ambiguity caused by airborne LiDAR caused by residual vibration after high-frequency vibration is suppressed by a vibration-damping platform, established a stochastic vibration fuzzy theoretical model, analyzed the mechanism of crosstalk effect between pixels, and studied the relationship between exposure time, pixel crosstalk radius and relative ranging error coefficient. The optimal exposure time satisfying the resolution requirement is obtained, and the ranging performance of the system is improved. Hong et al. [32,33] conducted a focused study on how vibration affects the measurement accuracy of LiDAR. They examined the influence of both platform angular vibration and linear vibration, establishing a mathematical model for angular vibration. Their findings revealed that vertical vibrations have a more significant impact on image quality compared to vibrations along the horizontal route. In theoretical analysis, simulation, or modeling, the above methods all set relatively ideal assumptions, which are difficult to meet in practical engineering applications.
In terms of hardware, Song et al. [34] designed a LiDAR vibration-damping platform by comprehensively adopting an aluminum alloy frame, an optical platform, and a wire rope shock absorber to solve the vibration problem of vehicle-mounted LiDAR. Through experimental verification, the platform can effectively reduce the impact of vibration on the accuracy of LiDAR measurement. Veprik et al. [35] established an anti-vibration system model to solve the problem that optically sensitive parts were affected by vibration under harsh conditions. They selected wire rope shock absorbers for reasonable structural layout and design, which effectively suppressed the influence of vibration. In addition, to solve the vibration problem of key electronic equipment in harsh environments, they optimized the selection of elastic and damping shock absorbers and selected the best installation position of the vibration absorber according to the vibration response characteristics, thereby providing effective vibration protection for critical electronic components [36]. Aiming at the impact of vibration on the measurement accuracy of airborne vision sensors, Wang et al. [37] comprehensively compared the vibration damping performance and selected wire rope shock absorber with nonlinear hysteresis characteristics. They reasonably designed the shock absorber layout to avoid vibration coupling, effectively isolated the onboard vibration input, and improved the measurement accuracy and stability of the optoelectronic platform. Chen et al. [38] designed a reasonable layout of a metal wire rope shock absorber to solve the problem of vibration of vehicle-mounted LiDAR, designed a vibration reduction scheme for the optical platform, and effectively improved the measurement stability and accuracy. Li et al. [39], aiming at the imaging quality problem caused by the vibration of the airborne photoelectric detection platform, determined the installation position of the photoelectric detection platform by studying the carrier vibration environment. They established the vibration model of the vibration absorber of the photoelectric detection platform with the support of vibration theory and designed the vibration absorber. The experiment proved that the vibration absorber can effectively reduce the vibration intensity of the platform.
Try et al. [40] proposed a sensing device that combines a single six-axis IMU with a beam structure to achieve the measurement of tiny vibrations. Sun et al. [41] introduced a method for measuring ship ice-induced vibrations based on a miniature inertial sensing device. This method effectively collects acceleration data and enables real-time data storage through the integration of an internal inertial sensor module. Kaswekar et al. [42] proposed a comprehensive motion measurement method for real-time estimation of vibrations in the critical telescope of the stratospheric infrared observatory. Distributed inertial sensors were used to capture motion signals, while strain gauges also assisted in these measurements. The sensor fusion method developed consisted of a continuous–discrete extended Kalman filter. The above methods have a certain effect on vibration reduction, but it is difficult to quantify the actual vibration situation.
Table 2 summarizes the literature [23,24,25,26,27,28,29,30,31,32,33,34,35,36,37,38,39,43,44,45,46] and analyzes the research status of LiDAR vibration reduction technology.
Table 2.
Research status of LiDAR vibration reduction technology.
2.2. Research Status of LiDAR Dust Noise Reduction Technology
Stentz et al. [9] studied the problem of dust affecting loading target recognition in the automatic loading system of excavators. Based on the final echo technology, Anthony et al. improved the technology and distinguished the target and dust signals by extracting the edge of the final pulse, effectively improving the loading target recognition effect under the condition of dust. Phillips et al. [47] summarized the dust influence rules of common LiDAR under different measuring distances, different dust concentrations, and different reflectance of measured objects, aiming at the problems of terrain scanning reconstruction and loading target identification faced by excavators in the mine operating environment affected by dust. It provides a reference for how to make better use of LiDAR for distance measurement under dust conditions. At present, the research on laser radar dust noise reduction technology for intelligent excavators is still relatively lacking, but the relevant research in other fields has certain reference significance for the development of intelligent excavators.
Laux et al. [48] conducted a detailed experimental analysis to address the issue of adverse environmental conditions, such as smoke and dust, which negatively impact the performance of sensors like radar and cameras. Their study demonstrated that fusing two-dimensional color images with three-dimensional point cloud registration can effectively reduce noise and enhance environmental perception capabilities. Cao et al. [49] calculated the noise level according to the LiDAR equation, and verified the background noise equation by using the observed LiDAR data and the simulated signal, indicating that the equation provides a reasonable method for measuring the background noise level of LiDAR data. Cheng et al. [50] proposed a LiDAR denoising method based on differential optical path, derived and verified the mathematical model, and simulated the signal-to-noise ratio based on this method. Goodin et al. [51] established a probabilistic model of the interaction between LiDAR and dust and verified the model through simulation and experiment. Ryde et al. [52] developed a method to measure the level of suspended dust by determining the transmission coefficient and used it for quantitative evaluation of the environmental perception performance of LiDAR. The reliability and accuracy of target detection were evaluated by conducting measurement experiments with sensors in a controlled environment. The above methods focus on evaluating the impact of smoke, dust, etc. on the sensor’s environment perception through techniques such as simulation or modeling. However, all of them adopt ideal assumptions, which are difficult to meet in practical engineering applications.
Because the dust will make the light emitted by the LiDAR offset, it is easy to cause the outlier. From the perspective of filtering and noise reduction, Du et al. [53] carried out filtering and noise reduction for point clouds based on a bilateral filtering algorithm while maintaining the characteristics of point clouds. The algorithm fully considered the normal variation of the surface of the point cloud model and the relationship between the distance between neighboring points and noise and realized point cloud noise reduction by adjusting the normal position of sampling points. Cao et al. [54] used the improved bilateral filtering algorithm to remove the point cloud noise. First, the point was judged to be a feature point or a non-feature point. Then, the bilateral filtering factors of feature points and non-feature points were calculated according to the point clouds in different ranges. In this way, bilateral filtering point cloud denoising based on feature selection is achieved, which effectively maintains the features of the scanned object while removing the noise. Wu et al. [55] proposed a 3D point cloud denoising algorithm based on feature information classification. The principal component analysis method and quadric surface fitting method were integrated to estimate the geometric information of 3D point clouds, and then point clouds were divided into regions with rich feature information and regions with less feature information according to the average curvature of point clouds. Adaptive bilateral filtering algorithm and neighborhood distance average filtering algorithm were used to reduce noise in different regions. Table 3 summarizes the methods proposed in the literature [9,47,48,49,50,51,52,53,54,55,56,57,58,59]. All the above methods adopt noise reduction filtering to filter the noise generated under the influence of harsh environments. However, the data generated after noise filtering were not effectively repaired.
Table 3.
Research status of LiDAR dust reduction technology.
2.3. Research Status of Multi-Sensor Information Fusion Technology
Yamamoto et al. [15] comprehensively adopted monocular cameras, binocular stereo cameras, and LiDAR as environmental sensing devices to develop an autonomous intelligent excavator based on a comprehensive sensing system. Through multi-sensor information fusion, they realized the detection of obstacles and mining targets in the mining operation scene and the real-time three-dimensional modeling of mining results. Kwon et al. [17], addressing the challenge of complex and dynamic environments that are difficult to perceive during earthmoving operations of intelligent excavators, employed both cameras and LiDAR to sense the surroundings. They used the iterative closest point (ICP) algorithm to fuse image and point cloud data, effectively enhancing the environmental perception capabilities of the excavator during operation. Yoo et al. [60] developed a local terrain reconstruction system for intelligent excavators by comprehensively using LiDAR and binocular cameras, which effectively improved the environmental perception ability of intelligent excavators. At present, the research on multi-sensor information fusion technology for intelligent excavators is still relatively lacking, but the relevant research in other fields also has certain reference significance for the research and development of intelligent excavators.
Graeter et al. [61,62] comprehensively adopted LiDAR and a camera for data acquisition, and projected point cloud data onto images for data fusion, which added depth information to image pixels and effectively improved the ability of environmental perception. However, the resolution of the camera was higher than that of the radar, resulting in the loss of depth information of some image pixels. To solve the problem of resolution matching between LiDAR and the camera, De Silva et al. [63] calculated the geometric transformation relationship between different sensors and adopted the Gaussian interpolation algorithm to compensate for the image pixels lacking depth information, effectively improving the feature representation ability of data fusion. To meet the environmental perception requirements of auto-autonomous driving, Akhtar et al. [64] fused lidar point cloud data with camera image data, allocated color information to the point cloud and formed a 3D model. They assign the depth information to the image pixels to form a depth map. At the same time, to match the resolution of lidar data and image data, Gaussian process regression was used to interpolate the depth map. Lee et al. [65] proposed a new method to reconstruct 3D scenes by integrating data from different types of sensors, which mainly includes two main stages: local distance modeling and 3D depth map reconstruction. In the local range modeling stage, Gaussian process regression interpolation is used to perform the difference of 3D point clouds. In the reconstruction stage, images and interpolation points are fused. A 3D depth map is built, and the data are optimized based on Markov random fields. An et al. [66] developed an all-around three-dimensional color laser ranging system using a two-dimensional laser rangefinder, a color camera, and a rotating platform. Based on the improved rectangular hole checkerboard calibration method, two-dimensional images, and point clouds were fused into three-dimensional color point clouds.
In terms of building environmental perception, Yang et al. [67] proposed a method that uses LiDAR and image data fusion for feature extraction and three-dimensional reconstruction of conventional building surfaces. They extracted initial features from images according to gradient direction and realized the conversion of 2D image features to 3D point cloud space based on registration. Finally, plane-fitting of the point cloud data around the feature lines was carried out to achieve better model reconstruction. Li et al. [68] made full use of the complementary advantages of LiDAR data and optical imaging to extract different building features from the two data sources and fuse them to form the final complete building boundary. This method can automatically and accurately extract building boundaries of complex shapes and has strong robustness in complex environments.
In terms of the outdoor environmental perception of robots, Yu et al. [69] proposed a positioning algorithm based on the fusion of camera and LiDAR. By combining the depth information of LiDAR with the color texture information of the image, a feature point matching relationship is established. This method solves the localization problem of outdoor robots under the influence of complex environmental factors such as light and ground fluctuation. Wang et al. [70] fused visual information, LiDAR information, and odometer information to solve the problem of timely positioning and accurate composition of mobile robots in unknown environments. Experiments proved that multi-sensor information fusion can make the composition more accurate and robust.
In terms of unmanned road environmental perception, Qu et al. [71] fused LiDAR depth information by mapping it to two-dimensional camera images and realized real-time pedestrian detection through cluster analysis and support vector machine classification. Wu et al. [72] proposed a real-time vehicle detection method based on the fusion of radar and vision sensors. Hough transform and Chebyshev’s theorem were used to filter the non-target points in the LiDAR data channel, significant vehicle images were generated in the image data channel, and the vehicle position was located by segmentation method. Table 4 summarizes the methods proposed in the literature [15,57,58,59,60,61,62,63,64,65,66,67,68,69,70,71,72,73,74,75,76]. At present, most of the multi-sensor information fusion technologies use LiDAR and cameras for fusion, and the mode is relatively simple. More model data need to be added for the necessary supplement to express the measured target more comprehensively.
Table 4.
Research status of multi-sensor fusion technology.
2.4. Research Status of Segmentation and Recognition Technology of 3D Operation Scenes
The three-dimensional point cloud can accurately record the location and geometric information of the measured target; it has advantages that two-dimensional images cannot match. This important information is the basis for intelligent excavators to carry out tasks such as path planning and trajectory planning, so the intelligent excavator operation scene perception data is mainly the three-dimensional point cloud. The three-dimensional operation scene of intelligent excavators is complex and dynamic, and the main targets to be divided and identified include piles, vehicles, personnel, trees, buildings, ground, etc., which is extensive and diverse.
Aiming at the segmentation and recognition of the intelligent excavator’s three-dimensional operation scene, Yang et al. [77] proposed a multi-scale edge detection algorithm by constructing a quadratic B-spline wavelet. Based on this algorithm, the edge features of the loading vehicle of an intelligent excavator were detected and recognized. Zhu et al. [78] proposed a method based on point cloud clustering feature histogram for the identification of intelligent excavator operation targets. This method can simultaneously identify multiple targets such as intelligent excavator loading vehicles and material piles and has good stability. Aiming at intelligent mining excavators under the influence of dust, Phillips et al. [79] proposed a target segmentation and identification method based on maximum evidence, which improved the accuracy and robustness of segmentation and identification. This method achieves the segmentation and recognition of operational targets such as buckets and piles. In addition, aiming at the anti-collision problem of mining excavator buckets and mining cards, they divided and identified the edges of buckets and mining cards [80]. At present, there are few research results on the segmentation and recognition technology for the three-dimensional operation of intelligent excavators, but relevant research in other fields can have certain reference significance for the research and development of intelligent excavators. This research can be divided into traditional machine learning algorithms and deep learning algorithms.
The traditional machine learning algorithm extracts sample features and uses the classifier to complete the segmentation and recognition of 3D job scenes. The use of Markov random fields [81], random forests [82], support vector machines [83,84] and other models has improved the recognition speed and accuracy. Niemeyer et al. [85] comprehensively adopted a random forest classifier and conditional random field and used reflection intensity, curvature and other features to identify buildings in three-dimensional point cloud scenes. Golovinskin et al. [86] used the graph-cutting method to segment the point cloud scene, and then extracted features such as target location and nearest distance to the roadside, and applied a support vector machine to classify and recognize objects such as vehicles and street lights. Yao et al. [87] extracted spectral, geometric, and spatial features of 3D point cloud data, and then used the AdaBoost classifier to extract trees from urban scenes. Zhao et al. [88] segmented a three-dimensional point cloud using the scanning line algorithm and extract the height of the segmented surface, normal vector variance, and other features. They also used a support vector machine to classify and recognize targets such as pedestrians and trees. Wang et al. [89] segmented point cloud data after the removal of ground points through raster processing, and set the grid and its neighborhood as local point clouds. Then, they extracted the reflective features of the local point cloud and used Hof forest to segment and identify the targets such as trees and vehicles in the urban environment. Wang et al. [90] conducted multi-scale sampling of point cloud data and classified the sampling points into different levels of point cloud clusters. Then, vehicles, pedestrians, buildings, and other targets in the urban scene were identified based on the Bayesian probabilistic model and AdaBoost classifier. Traditional machine learning algorithms rely heavily on artificial feature extraction. It is difficult to extract complex features accurately, resulting in lower segmentation recognition accuracy.
Deep learning algorithms can be divided into two categories according to the different processing methods of the point cloud. One is to regularize the disordered point cloud first, such as projecting a 3D point cloud onto a 2D plane [91,92,93,94,95]. Alternatively, the disordered point cloud is rasterized and voxelized [96,97,98,99], and then processed by convolutional neural networks (CNNS). This kind of algorithm is easier to understand, and can effectively combine the successful experience of a two-dimensional image semantic segmentation algorithm to easily transplant the image semantic segmentation algorithm to three-dimensional point cloud semantic segmentation. However, point cloud preprocessing will lose certain point cloud information, which will have adverse effects on point cloud feature extraction, especially point cloud processing in fine-grained complex scenes [100]. The other type directly processes the original point cloud data and does not transform the point cloud data before input to the network to save the point cloud information to the maximum extent. This type of algorithm has strong anti-noise ability and a high intelligence degree and can obtain relatively robust and accurate segmentation and recognition results for point clouds with different quality and density distributions. It is more in line with the need for intelligent autonomous operation of excavators.
PointNet, proposed by Qi et al. [101], was the first network to directly input original point cloud data for segmentation and recognition. This network solved problems such as point cloud disorder and geometric rotation invariance, and the experimental results showed that breakthrough progress had been made in both point cloud classification and semantic segmentation. However, the algorithm does not make use of local feature information effectively, and the perception ability of local spatial features is poor. To solve the problems existing in PointNet, Qi et al. [102] proposed PointNet++ and constructed a hierarchical neural network structure. At each layer, point clouds were first sampled and divided into regions, and then the basic PointNet network was used to extract local features in each region. These local features are then further sampled and zoned as part of the input to extract higher-level features. Pointnet ++ improves the ability to extract local features of the point cloud and effectively improves the segmentation and recognition effect of point cloud targets such as walls and roofs. Jiang et al. [103] proposed PointSIFT, a three-dimensional point cloud segmentation model based on scale-invariant feature transformation. In this model, multiple main direction information points are encoded by directional coding units, and multiple coding units are stacked to obtain multi-scale features. Zhao et al. [104] proposed a PointWeb 3D point cloud segmentation model, which connected each point in the local neighborhood to better extract local point cloud features, and proposed an adaptive feature adjustment module to enhance point-by-point feature expression capability. Wang et al. [105] from MIT applied graph convolutional neural network to 3D point cloud processing based on PointNet, and proposed DGCNN, a dynamic graph volume point cloud processing algorithm, which effectively solved the problem of poor perception of local spatial features of PointNet, and greatly improved its point cloud classification and segmentation ability and robustness. To improve the efficiency of semantic segmentation of three-dimensional point clouds in large scenes, Hu et al. [106] proposed RandLA-Net, which selected the most efficient random sampling by comparing existing sampling methods. They proposed a local feature sampler to reduce the information lost by random sampling. The network realizes efficient segmentation and identification of objects such as cars and trees in the cloud data of outdoor scenic spots.
Ren et al. [107] introduced a multi-modal feature fusion network (MFFNet) for 3D point cloud semantic segmentation. Unlike the previous approach of learning directly from colored point clouds (XYZRGB), MFFNet converts point clouds into 2D RGB images and frequency image representations for efficient multimodal feature fusion. Poliyapram et al. [108] proposed a novel end-to-end point-by-point LiDAR and image multimodal fusion network (PMNet) based on deep learning, which is used to fuse aerial image features for 3D segmentation of aerial point clouds. Due to the low resolution of the point cloud model and the lack of spatial location information of the image model, a single model cannot accurately calculate ore fragmentation. To solve this problem, Peng et al. [109] proposed an ore fragmentation calculation method (ORFCM) based on the multi-modal fusion of point cloud and image. ORFCM takes full advantage of multi-modal data, including fine-grained object segmentation of images and spatial location information of point clouds. An et al. [110] proposed a multi-level framework for three-dimensional point cloud ground segmentation of outdoor scenes based on shape analysis. The method explores the local shape and multilevel structure of the outdoor scene and constructs a probabilistic ground model to improve the accuracy and adaptability of the ground segmentation. Hu et al. [111] proposed a semantic segmentation network for outdoor panoramic images based on distorted convolution. In this network, the distortion convolution module (DCM) and depth feature aggregation network (DFAN) are introduced into the semantic segmentation of panoramic images, which improves the segmentation accuracy. Table 5 summarizes the methods proposed in the literature [77,78,79,80,85,86,87,88,89,90,101,102,103,104,105,106,109,112,113,114,115]. All of the above deep learning methods rely on a large set of labeled data. However, the process of data set annotation is time-consuming and labor-intensive, and the degree of automation is low. Therefore, the development of deep learning algorithms is limited.
Table 5.
Research status of segmentation and recognition technology for 3D scenes.
3. Research Prospect of Key Technologies of Intelligent Excavator Environmental Perception
3.1. Research Prospect of LiDAR Vibration Reduction Technology
Although the existing achievements can provide some reference for the research on the LiDAR vibration reduction technology of intelligent excavators, its research background is mainly aimed at the airborne and general vehicle environment. Intelligent excavators have unique vibration characteristics, so the subsequent research on vibration reduction of intelligent excavators needs to be carried out according to the vibration characteristics of intelligent excavators. The research prospects are as follows.
3.1.1. Experimental Measurement of Vibration
The vibration test and measurement method of intelligent excavators are studied. The appropriate vibration meter is selected according to the excavator’s main vibration parameters, such as vibration frequency and amplitude, and a detailed vibration measurement scheme is developed. The vibration parameters are measured at the installation position of important environmental sensing sensors, which provides data support for the establishment of a vibration analysis model and the design of a vibration damping table.
3.1.2. The Vibration Analysis Model Is Established
According to the measurement data of the excavator vibration experiment, the vibration analysis model is studied and established. Analyzing the influence of the stiffness and damping of the shock absorber on the performance of the vibration absorber provides theoretical and data support for the design of the vibration absorber.
3.1.3. Vibration Mechanism Analysis
By collecting vibration data in the process of operation, the vibration signal is converted into frequency domain information through spectrum analysis. Different frequency components are identified. Each frequency peak in the spectrogram was analyzed to reveal the characteristics of the vibration.
3.1.4. Hardware Design of Vibration Reduction Platform
Based on the above theoretical results, the design method of a shock absorber is studied, including scheme design, shock absorber selection, shock absorber layout, and installation mode. Considering the installation space, the vibration excitation in the working environment, and the natural frequency and vibration transmission of the shock absorber, the appropriate type of shock absorber is selected. The reasonable design of the shock absorber layout ensures that linear vibration and angular vibration are sufficiently decoupled to avoid large angular vibration. In addition, it is also necessary to fully consider the installation space limitation, maintainability, manufacturability, and other aspects. To verify the damping effect of the damping table on 3D LiDAR, a random vibration test was carried out. The vibration table generates random vibration excitation along the horizontal direction and vertical direction, respectively, and the acceleration response of the vibration absorbing table in different directions is obtained through the measuring point. According to the amplitude change of the excitation signal and response signal in the random vibration test, the damping effect of the damping table can be measured.
3.1.5. Point Cloud Vibration Error Correction
The method of point cloud vibration error correction is explored. The position and posture sensor are used to measure the displacement and attitude angle of LiDAR relative to the installation platform of the excavator under vibration conditions, and the error transfer model is established to correct the three-dimensional point cloud data affected by vibration.
3.2. Research Prospects of LiDAR Dust Noise Reduction Technology
At present, LiDAR dust and noise reduction technology has a certain research foundation. However, there are fewer studies on the operating environment of intelligent excavators, and most of them use experimental analysis methods, and the effect of dust and noise reduction is seriously dependent on hardware. Combined with the characteristics of the operating environment of intelligent excavators and the research achievements of LiDAR dust and noise reduction technology in other fields, the research prospects are as follows:
3.2.1. Final Echo Technique
The measurement principles and hardware characteristics of different types of LiDAR were studied and analyzed. For three-dimensional LiDAR with multiple echo technology, the point cloud data obtained from the last echo were selected as the target point cloud data. This minimizes the effect of dust on the accuracy of 3D LIDAR environmental measurements at the hardware level.
3.2.2. Compare and Select the Best Quality Point Cloud Data
Since the concentration and distribution of dust in the air have dynamic characteristics and will change with the change of time, it is possible to select a reasonable installation position through experimental research and install multiple sets of LiDAR on the intelligent excavator. From the multi-frame point cloud data collected at different locations at different times, the environmental point cloud data with the best quality and the least influence of dust is selected as the main point cloud data. At the same time, aiming at problems such as occlusion, the registration fusion method is studied, and other point cloud data collected at the same time are used to compensate and repair them.
3.2.3. Filtering and Noise Reduction Based on Multi-Modal Fusion
The point cloud is fused with the image information to extract the color, texture, and other details of the dust noise. By comprehensively comparing the typical three-dimensional point cloud filtering algorithms such as bilateral filtering and statistical filtering, the best algorithm is selected to filter the point cloud and remove the dust noise based on protecting the important features of the point cloud.
3.2.4. Sparse Repair
Aiming at the point cloud sparsity caused by point cloud filtering and noise reduction, the interpolation method is studied to repair the sparsity of the point cloud, to ensure the expression ability of the three-dimensional point cloud for a real mining environment to the greatest extent. For example, moving least squares algorithms fill holes or sparse areas by locally fitting smooth surfaces. By least square fitting in the neighborhood, the surface of the point cloud is smooth and close to the original point cloud.
3.3. Research Prospect of Multi-Sensor Information Fusion Technology
Intelligent excavators have the characteristics of complex working environments and a wide range of working scenes, which determine that more types and more sensors are needed for intelligent excavators’ environmental perception, which brings great challenges to multi-sensor information fusion. Combined with the characteristics of the operating environment of intelligent excavators and the existing research results of multi-sensor information fusion technology, the research prospects are as follows.
3.3.1. Sensor Calibration
In order to overcome the lack of information acquisition ability of a single sensor and make the intelligent excavator have better environmental perception ability, a calibration tool suitable for the working environment of the intelligent excavator is designed. The internal and external calibration methods for both the camera and LiDAR are investigated to accurately determine the internal parameters of the camera and the external parameters of both the camera and LiDAR. This enables the construction of a mapping relationship between the laser points and pixel coordinates. Sensor calibration is the basis and key to realizing point cloud and image fusion and obtaining 3D color point cloud data, so it is very important to study this technology.
3.3.2. Data Synchronization
To realize the intelligent excavator’s all-around perception of a wide range of operation scenarios, the data synchronization module was developed using the precision time protocol (PTP), presentation time stamp (PTS), and hardware trigger methods to achieve high-precision synchronization of sensors such as LiDAR, camera, GPS, inertial measurement unit (IMU), etc. Data synchronization is the key to realizing multi-view three-dimensional color point cloud data fusion, and the accuracy of data synchronization directly determines the all-around perception accuracy of intelligent excavators for a wide range of work scenes. Therefore, it is necessary to conduct in-depth research on this technology.
3.3.3. Multiple Sight Registration
To obtain the complete three-dimensional point cloud data of the large-scale operation scene of the intelligent excavator, it is necessary to conduct multi-angle scanning of the operation scene. Therefore, we need to study the multiple-view registration method, accurately register the multiple-view laser point cloud under the unified coordinate system, and realize the integration of large-scale operation scenery. However, most of the existing registration methods are subject to too much interference from human factors, and there is still a gap between the registration accuracy and efficiency and the practical application requirements. So, it is of great practical significance to study the high-precision and high-efficiency 3D point cloud multi-view registration method with a higher degree of automation.
3.4. Research Prospect of 3D Operation Scene Segmentation and Recognition Technology
The working environment of intelligent excavators is complex, and the working target is dynamic and changeable, which brings great challenges to the segmentation and recognition of 3D working scenes. Combined with the characteristics of the operating environment of intelligent excavators and the existing research results of multi-three-dimensional scene segmentation and recognition technology, the research prospects are as follows.
3.4.1. Point Cloud Data Feature Enhancement
Most of the original LiDAR point cloud data only have spatial coordinate information, and some can provide additional information about the reflection intensity of the target surface, but few features can be used. For complex terrain and targets, it is difficult to extract sufficient features for effective segmentation and recognition of point cloud data through nonlinear computing. The feature enhancement method of point cloud data can be studied. By analyzing the surface topography, physical features, dimensions, and other physical factors of intelligent excavator operation targets such as material piles, buckets, loading trucks, etc., representative features with physical significance and interpretability are designed. This can effectively enhance the features of the original data, which is conducive to improving the accuracy and robustness of segmentation recognition.
3.4.2. Network Structure Design
The operation scene of intelligent excavators is complex, large-scale, and dynamic, which poses great challenges to the accuracy and efficiency of 3D scene segmentation and recognition. Building on the successful application of the attention mechanism [116,117,118,119,120,121] in 2D image processing, this paper explores a method to incorporate the attention mechanism into 3D deep learning semantic segmentation. By assigning different weights to various features, the approach enhances the contribution of effective features while suppressing the influence of ineffective ones. The accuracy of 3D scene segmentation recognition is higher through feature re-calibration.
In addition, we can learn from the successful experience of the lightweight network [122,123,124,125,126] in two-dimensional image processing to explore the lightweight mechanism suitable for a three-dimensional deep-learning semantic segmentation algorithm. The computational complexity of the algorithm is reduced by changing the convolution mode, using convolution instead of full join, and designing an efficient sampling mode. These methods can also reduce the number of parameters and improve the efficiency of segmentation recognition.
3.4.3. Online Learning Style Changes
The intelligent excavator 3D operation scenario has a large range, many targets, a large amount of point cloud data, and a high cost of 3D data annotation, which has a great impact on the application of conventional deep learning algorithms. However, by changing the learning mode and exploring and studying weakly supervised, small sample learning algorithms or unsupervised self-learning algorithms, the workload of data annotation can be effectively reduced. Currently, there is little research on this type of deep learning algorithm, which has a very broad research value and application prospect.
4. Conclusions
Environmental perception is a hot and difficult research topic in the field of intelligent excavators. This paper summarizes and analyzes this problem in detail. Firstly, the main system composition of the intelligent excavator is introduced, and by summarizing the research status of the intelligent excavator, it is found that there is still a large gap in the current research on the environmental perception system. Thus, there is an urgent need to carry out in-depth research and discussion on the key technology of environmental perception of intelligent excavators. Secondly, by analyzing the characteristics of the operating environment of intelligent excavators, the key technologies that need to be solved urgently for the environmental perception of intelligent excavators are proposed. These technologies include LiDAR vibration reduction, LiDAR dust and noise reduction, multi-sensor information fusion, 3D operation scene segmentation and recognition, etc. In addition, the research status at home and abroad is summarized in detail because of these key issues. Finally, follow-up research on the key technology of environmental perception of intelligent excavators is recommended.
Funding
This work was supported in part by the National Natural Science Foundation of China under Grant 62173055, in part by the Henan Province Science and Technology Research and Development Plan Joint Fund Project under Grant 225101610001, in part by the Natural Science Foundation Program of Liaoning Province under Grant 2023-MS-093, in part by the Science and Technology Major Project of Shanxi Province under Grant 20191101014, and in part by the Science and Technology Major Project of Xinjiang Uygur Autonomous Region under Grant 2023A01005.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Shi, Y.; Xia, Y.; Zhang, Y.; Yao, Z. Intelligent Identification for Working-Cycle Stages of Excavator Based on Main Pump Pressure. Autom. Constr. 2020, 109, 102991. [Google Scholar] [CrossRef] [Scilit]
- He, X.; Jiang, Y. Review of Hybrid Electric Systems for Construction Machinery. Autom. Constr. 2018, 92, 286–296. [Google Scholar] [CrossRef] [Scilit]
- Yusof, A.A.; Saadun, M.N.A.; Sulaiman, H.; Sabaruddin, S.A. The Development of Tele-Operated Electro-Hydraulic Actuator (T-EHA) for Mini Excavator Tele-Operation. In Proceedings of the 2016 2nd IEEE International Symposium on Robotics and Manufacturing Automation (ROMA), Ipoh, Malaysia, 25–27 September 2016; pp. 1–6. [Google Scholar]
- Papadopoulos, E.; Mu, B.; Frenette, R. On Modeling, Identification, and Control of a Heavy-Duty Electrohydraulic Harvester Manipulator. IEEE/ASME Trans. Mechatron. 2003, 8, 178–187. [Google Scholar] [CrossRef]
- Lee, S.U.; Chang, P.H. Control of a Heavy-Duty Robotic Excavator Using Time Delay Control with Integral Sliding Surface. Control Eng. Pract. 2002, 10, 697–711. [Google Scholar] [CrossRef] [Scilit]
- Bradley, D.A.; Seward, D.W. Developing Real-Time Autonomous Excavation-the LUCIE Story. In Proceedings of the 1995 34th IEEE Conference on Decision and Control, New Orleans, LA, USA, 13–15 December 1995; Volume 3, pp. 3028–3033. [Google Scholar]
- Seward, D.; Margrave, F.; Sommerville, I.; Morrey, R. LUCIE the Robot Excavator-Design for System Safety. In Proceedings of the IEEE International Conference on Robotics and Automation, Minneapolis, MN, USA, 22–28 April 1996; Volume 1, pp. 963–968. [Google Scholar]
- Seward, D.; Pace, C.; Morrey, R.; Sommerville, I. Safety Analysis of Autonomous Excavator Functionality. Reliab. Eng. Syst. Saf. 2000, 70, 29–39. [Google Scholar] [CrossRef] [Scilit]
- Stentz, A.; Bares, J.; Singh, S.; Rowe, P. A Robotic Excavator for Autonomous Truck Loading. Auton. Robot. 1999, 7, 175–186. [Google Scholar] [CrossRef] [Scilit]
- Patrick, R. Adaptive Motion Planning for Autonomous Mass Excavation. Ph.D. Thesis, Carnegie Mellon University, Pittsburgh, PN, USA, 1999. [Google Scholar]
- Ha, Q.P.; Nguyen, Q.H.; Rye, D.C.; Durrant-Whyte, H.F. Impedance Control of a Hydraulically Actuated Robotic Excavator. Autom. Constr. 2000, 9, 421–435. [Google Scholar] [CrossRef] [Scilit]
- Ha, Q.P.; Rye, D.C. A Control Architecture for Robotic Excavation in Construction. Comput. Aided Civ. Eng. 2004, 19, 28–41. [Google Scholar] [CrossRef] [Scilit]
- Dunbabin, M.; Corke, P. Autonomous Excavation Using a Rope Shovel. J. Field Robot. 2006, 23, 379–394. [Google Scholar] [CrossRef] [Scilit]
- Gu, Y.M. Research on Image Processing Technology in Vision Systems of Intelligent Excavators. Ph.D. Thesis, Northeastern University, Shenyang, China, 2009. [Google Scholar]
- Yamamoto, H.; Moteki, M.; Ootuki, T.; Yanagisawa, Y.; Nozue, A.; Yamaguchi, T.; Yuta, S. Development of the Autonomous Hydraulic Excavator Prototype Using 3-D Information for Motion Planning and Control. Trans. Soc. Instrum. Control Eng. 2012, 48, 488–497. [Google Scholar] [CrossRef] [Scilit]
- He, J.L.; Zhao, X.; Zhang, D.Q.; Song, J. Research on Automatic Trajectory Control of a New Intelligent Excavator. J. Guangxi Univ. 2012, 37, 259–265. [Google Scholar]
- Kwon, S.; Lee, M.; Lee, M.; Lee, S.; Lee, J. Development of Optimized Point Cloud Merging Algorithms for Accurate Processing to Create Earthwork Site Models. Autom. Constr. 2013, 35, 618–624. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Sun, W.; Li, E.; Song, X. Energy-Minimum Optimization of the Intelligent Excavating Process for Large Cable Shovel through Trajectory Planning. Struct. Multidisc. Optim. 2018, 58, 2219–2237. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.Z. Trajectory Planning and Task Decision Making of Intelligent Excavator Robots. Master’s Thesis, Zhejiang University, Hangzhou, China, 2019. [Google Scholar]
- Sun, H.Y. Identification of Typical Operational Stages and Trajectory Control of Work Devices for Intelligent Excavators. Master’s Thesis, Harbin Institute of Technology, Harbin, China, 2021. [Google Scholar]
- Liu, W.S. 3D Point Cloud-Based Perception of the Working Environment for Intelligent Mining Excavator. Master’s Thesis, Dalian University of Technology, Dalian, China, 2022. [Google Scholar]
- Zhang, T.; Fu, T.; Ni, T.; Yue, H.; Wang, Y.; Song, X. Data-Driven Excavation Trajectory Planning for Unmanned Mining Excavator. Autom. Constr. 2024, 162, 105395. [Google Scholar] [CrossRef] [Scilit]
- Chen, F.Y.; Li, L. Development of a Vibration Monitoring Recorder for Mining Excavators. J. Inn. Mong. Univ. Nat. 2019, 34, 242–244. [Google Scholar]
- Huang, Z.X.; He, Q.H. Denoising of Vibration Signals in the Hydraulic Excavator Backhoe Digging Process. J. Cent. South Univ. 2013, 44, 2267–2273. [Google Scholar]
- Zhou, J.; Chen, J. Analysis and Optimization Design of Noise and Vibration Characteristics in Excavator Cabins. Noise Vib. Control 2013, 33, 87–90. [Google Scholar]
- Zhang, Y.M. Vibration Study of Lifting Mechanism in Large Mining Excavators. J. Mech. Eng. Autom. 2017, 2, 4–5. [Google Scholar]
- Ma, H.; Wu, J. Analysis of Positioning Errors Caused by Platform Vibration of Airborne LiDAR System. In Proceedings of the 2012 8th IEEE International Symposium on Instrumentation and Control Technology, London, UK, 11–13 July 2012; pp. 257–261. [Google Scholar]
- Ma, M.; Li, D.; Du, J. Image Processing of Airborne Synthetic Aperture Laser Radar Under Vibration Conditions. J. Radars 2014, 3, 591–602. [Google Scholar] [CrossRef] [Scilit]
- Hu, X.; Li, D.; Du, J.; Ma, M.; Zhou, J. Vibration Estimation of Synthetic Aperture Lidar Based on Division of Inner View Field by Two Detectors along Track. In Proceedings of the 2016 IEEE International Geoscience and Remote Sensing Symposium, Beijing, China, 10–15 July 2016; pp. 4561–4564. [Google Scholar]
- Cui, S.; Qi, X.; Wang, X. Research on Impact Vibration Noise Reduction Method for Vehicle-Borne Laser Radar Based on Wavelet Analysis. Automob. Technol. 2017, 10, 24–28. [Google Scholar]
- Su, H.; Yan, H.; Zhang, X.; Yang, C. Study on Laser Radar Imaging Blur Induced by Residual Vibration. Infrared Laser Eng. 2011, 40, 2174–2179. [Google Scholar]
- Hong, G.; Guo, L. Analysis of the Effect of Linear Vibration on Synthetic Aperture Laser Radar Imaging. Acta Opt. Sin. 2012, 32, 0428001. [Google Scholar] [CrossRef] [Scilit]
- Hong, G.; Guo, L. E Influence of Angular Vibration on Synthetic Aperture Laser Radar Imaging. J. Infrared Millim. Waves 2011, 30, 571–576. [Google Scholar] [CrossRef] [Scilit]
- Song, X.; Chen, C.; Liu, B.; Xia, J.; Stanic, S. Design and Implementation of Vibration Isolation System for Mobile Doppler Wind LIDAR. J. Opt. Soc. Korea JOSK 2013, 17, 103–108. [Google Scholar] [CrossRef] [Scilit]
- Veprik, A.M.; Babitsky, V.I.; Pundak, N.; Riabzev, S.V. Vibration Protection of Sensitive Components of Infrared Equipment in Harsh Environments. Shock Vib. 2001, 8, 55–69. [Google Scholar] [CrossRef] [Scilit]
- Veprik, A.M. Vibration Protection of Critical Components of Electronic Equipment in Harsh Environmental Conditions. J. Sound Vib. 2003, 259, 161–175. [Google Scholar] [CrossRef] [Scilit]
- Wang, P.; Wang, W.; Ding, J. Design of Composite Vibration Isolation for Airborne Electro-Optical Surveillance Platform. Opt. Precis. Eng. 2011, 19, 83–89. [Google Scholar] [CrossRef] [Scilit]
- Chen, C.; Song, X.; Xia, J. Vibration Isolation Design of Vehicle-Borne Doppler Wind Lidar System. J. Atmos. Environ. Opt. 2011, 19, 83–89. [Google Scholar]
- Li, Y. Studies on Environmental Adaptability of Airborne Electro-Optical Reconnaissance Platform. Ph.D. Thesis, University of Chinese Academy of Sciences, Beijing, China, 2014. [Google Scholar]
- Try, P.; Gebhard, M. A Vibration Sensing Device Using a Six-Axis IMU and an Optimized Beam Structure for Activity Monitoring. Sensors 2023, 23, 8045. [Google Scholar] [CrossRef] [Scilit]
- Sun, Z.; Wu, Z.; Ren, X.; Zhao, Y. IMU Sensor-Based Vibration Measuring of Ship Sailing. In Proceedings of the 2021 IEEE 11th Annual International Conference on CYBER Technology in Automation, Control, and Intelligent Systems, Jiaxing, China, 27–31 July 2021; pp. 845–849. [Google Scholar]
- Kaswekar, P.; Wagner, J.F. Sensor Fusion Based Vibration Estimation Using Inertial Sensors for a Complex Lightweight Structure. In Proceedings of the 2015 DGON Inertial Sensors and Systems Symposium, Karlsruhe, Germany, 22–23 September 2015; pp. 1–20. [Google Scholar]
- Jin, L. Studies on Passive Vibration Isolation Method Using Second-Order Spring-Damping System for Lidar SLAM Mapping in Orchards. Master’s Thesis, Hangzhou University of Electronic Science and Technology, Hangzhou, China, 2024. [Google Scholar]
- Wang, H.N. Design, Modeling, and Experimental Validation of Rubber Vibration Isolator for UAV LiDAR. Master’s Thesis, Northeastern University, Nanjing, China, 2020. [Google Scholar]
- Li, D.; Liu, Z. Studies on Multi-Modal Vibration Suppression Algorithm for Hydraulic Excavator Track Chassis. Hydraul. Pneumat. Seals 2024, 44, 24–30. [Google Scholar]
- Lu, C.; Chai, P.; Liu, Z.; Liu, Y. Study on Noise and Vibration Performance of Excavator Based on Substructure Power Flow. J. Huazhong Univ. Sci. Technol. (Nat. Sci.) 2021, 49, 37–42. [Google Scholar]
- Phillips, T.G.; Guenther, N.; McAree, P.R. When the Dust Settles: The Four Behaviors of LiDAR in the Presence of Fine Airborne Particulates. J. Field Robot. 2017, 34, 985–1009. [Google Scholar] [CrossRef] [Scilit]
- Laux, T.E.; Chen, C. 3D Flash LIDAR Vision Systems for Imaging in Degraded Visual Environments. In Proceedings of the Degraded Visual Environments: Enhanced, Synthetic, and External Vision Solutions, Baltimore, MD, USA, 7–8 May 2014. [Google Scholar]
- Cao, N.; Zhu, C.; Kai, Y.; Yan, P. A Method of Background Noise Reduction in Lidar Data. Appl. Phys. B 2013, 113, 115–123. [Google Scholar] [CrossRef] [Scilit]
- Cheng, Y.; Cao, J.; Hao, Q.; Xiao, Y.; Zhang, F.; Xia, W.; Zhang, K.; Yu, H. A Novel De-Noising Method for Improving the Performance of Full-Waveform LiDAR Using Differential Optical Path. Remote Sens. 2017, 9, 1109. [Google Scholar] [CrossRef] [Scilit]
- Goodin, C.; Durst, P.J.; Prevost, Z.T.; Compton, P.J. A Probabilistic Model for Simulating the Effect of Airborne Dust on Ground-Based LIDAR. In Proceedings of the Active and Passive Signatures IV, Baltimore, MD, USA, 1–2 May 2013; Volume 8734, pp. 83–90. [Google Scholar]
- Ryde, J.; Hillier, N. Performance of Laser and Radar Ranging Devices in Adverse Environmental Conditions. J. Field Robot. 2009, 26, 712–727. [Google Scholar] [CrossRef] [Scilit]
- Du, X.; Jiang, X.; Hao, C.; Wang, Y. Bilateral Filtering Denoising Algorithm for Point Cloud Models. Comput. Appl. Softw. 2010, 27, 245–264. [Google Scholar]
- Cao, S.; Yue, J.; Ma, W. Bilateral Filtering Point Cloud Denoising Algorithm Based on Feature Selection. J. Southeast Univ. 2013, 43, 351–354. [Google Scholar]
- Wu, L.; Shi, H.; Chen, H. Feature-Based Classification for 3D Point Data Denoising. Opt. Precis. Eng. 2016, 24, 1465–1473. [Google Scholar]
- Li, S.; Mao, J.; Li, Z. An EEMD-SVD Method Based on Gray Wolf Optimization Algorithm for Lidar Signal Noise Reduction. Int. J. Remote Sens. 2023, 44, 5448–5472. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.; Chang, J.; Li, H.; Liu, Z.X.; Zhang, S.; Mao, R. Noise Reduction of LiDAR Signal via Local Mean Decomposition Combined with Improved Thresholding Method. IEEE Access 2020, 8, 113943–113952. [Google Scholar] [CrossRef] [Scilit]
- Dai, H.; Gao, C.; Lin, Z.; Wang, K.; Zhang, X. Wind Lidar Signal Denoising Method Based on Singular Value Decomposition and Variational Mode Decomposition. Appl. Opt. 2021, 60, 10721–10726. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, C.; Pan, Z.; Mao, F.; Gong, W.; Chen, S.; Min, Q. De-Noising and Retrieving Algorithm of Mie Lidar Data Based on the Particle Filter and the Fernald Method. Opt. Express 2015, 23, 26509. [Google Scholar] [CrossRef] [Scilit]
- Yoo, H.S.; Kim, Y.S. Development of a 3D Local Terrain Modeling System of Intelligent Excavation Robot. KSCE J. Civ. Eng. 2017, 21, 565–578. [Google Scholar] [CrossRef] [Scilit]
- Graeter, J.; Wilczynski, A.; Lauer, M. LIMO: Lidar-Monocular Visual Odometry. In Proceedings of the 2018 IEEE/RSJ International Conference on Intelligent Robots and Systems, Madrid, Spain, 1–5 October 2018; pp. 7872–7879. [Google Scholar]
- Shin, Y.S.; Park, Y.S.; Kim, A. Direct Visual SLAM Using Sparse Depth for Camera-LiDAR System. In Proceedings of the 2018 IEEE International Conference on Robotics and Automation, Brisbane, QLD, Australia, 21–25 May 2018; pp. 5144–5151. [Google Scholar]
- De Silva, V.; Roche, J.; Kondoz, A. Fusion of LiDAR and Camera Sensor Data for Environment Sensing in Driverless Vehicles. 2018; Preprint.
- Akhtar, M.R.; Qin, H.; Chen, G. Velodyne LiDAR and Monocular Camera Data Fusion for Depth Map and 3D Reconstruction. In Proceedings of the Eleventh International Conference on Digital Image Processing, Guangzhou, China, 10–13 May 2019; 2019; Volume 11179, pp. 87–97. [Google Scholar]
- Lee, H.; Song, S.; Jo, S. 3D Reconstruction Using a Sparse Laser Scanner and a Single Camera for Outdoor Autonomous Vehicle. In Proceedings of the 2016 IEEE 19th International Conference on Intelligent Transportation Systems, Rio de Janeiro, Brazil, 1–4 November 2016; pp. 629–634. [Google Scholar]
- An, Y.; Li, B.; Hu, H.; Zhou, X. Building an Omnidirectional 3-D Color Laser Ranging System Through a Novel Calibration Method. IEEE Trans. Ind. Electron. 2019, 66, 8821–8831. [Google Scholar] [CrossRef] [Scilit]
- Yang, L.; Sheng, Y.; Wang, B. 3D Reconstruction of Building Facade with Fused Data of Terrestrial LiDAR Data and Optical Image. Optik 2016, 127, 2165–2168. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Wu, H.; An, R.; Xu, H.; He, Q.; Xu, J. An Improved Building Boundary Extraction Algorithm Based on Fusion of Optical Imagery and LIDAR Data. Optik 2013, 124, 5357–5362. [Google Scholar] [CrossRef] [Scilit]
- Yu, Y.; Zhao, H. Localization in Unstructured Environments Based on Camera and Swing LiDAR Fusion. Acta Autom. Sin. 2019, 45, 1791–1798. [Google Scholar]
- Wang, X.; He, L.; Zhao, T. SLAM for Mobile Robots Based on LiDAR and Stereo Vision. J. Sens. Technol. 2019, 45, 1791–1798. [Google Scholar]
- Qu, Z.; Wei, F.; Wei, W.; Li, Z.; Hu, H. Pedestrian Detection Method Based on Fusion of Radar and Vision Information. J. Jilin Univ. 2019, 45, 1791–1798. [Google Scholar]
- Wu, G.; Zhao, C.; Liu, J.; Hu, B. Road Surface Vehicle Detection Based on Multi-Sensor Fusion. J. Huazhong Univ. Sci. Technol. 2015, 43, 250–262. [Google Scholar]
- Shao, P. Research on Multi-UAV SLAM Technology Based on Multi-Sensor Information Fusion. Master’s Thesis, University of Electronic Science and Technology, Chengdu, China, 2024. [Google Scholar]
- Zhao, Q.; Chen, H. Robot Motion Trajectory Tracking Based on Sensor Information Fusion. Inf. Technol. 2024, 182–186. [Google Scholar] [CrossRef]
- Quan, M. Research on Monocular Vision SLAM Algorithm Based on Multi-Sensor Information Fusion. Ph.D. Thesis, Harbin Institute of Technology, Harbin, China, 2021. [Google Scholar]
- Zhao, S. Research on Multi-Sensor Information Fusion Method for Intelligent Vehicles. Master’s Thesis, Jilin University, Changchun, China, 2020. [Google Scholar]
- Yang, L. Research on Target Recognition and Localization Technology for Autonomous Operation of Intelligent Excavators. Master’s Thesis, Jilin University, Changchun, China, 2004. [Google Scholar]
- Zhu, J.; Shen, D.; Wu, K. Target Recognition of Intelligent Excavators Based on LiDAR Point Clouds. Comput. Eng. 2017, 43, 297–302. [Google Scholar]
- Phillips, T.G.; McAree, P.R. An Evidence-Based Approach to Object Pose Estimation from LiDAR Measurements in Challenging Environments. J. Field Robot. 2018, 35, 921–936. [Google Scholar] [CrossRef] [Scilit]
- Phillips, T.G.; Green, M.E.; McAree, P.R. Is It What I Think It Is? Is It Where I Think It Is? Using Point-Clouds for Diagnostic Testing of a Digging Assembly’s Form and Pose for an Autonomous Mining Shovel. J. Field Robot. 2016, 33, 1013–1033. [Google Scholar] [CrossRef] [Scilit]
- Agrawal, A.; Nakazawa, A.; Takemura, H. MMM-Classification of 3D Range Data. In Proceedings of the 2009 IEEE International Conference on Robotics and Automation, Kobe, Japan, 12–17 May 2009; pp. 2003–2008. [Google Scholar]
- Zhu, J.; Pierskalla, W.P. Applying a Weighted Random Forests Method to Extract Karst Sinkholes from LiDAR Data. J. Hydrol. 2016, 533, 343–352. [Google Scholar] [CrossRef] [Scilit]
- Lai, X.; Yuan, Y.; Li, Y.; Wang, M. Full-Waveform LiDAR Point Clouds Classification Based on Wavelet Support Vector Machine and Ensemble Learning. Sensors 2019, 19, 3191. [Google Scholar] [CrossRef] [Scilit]
- Karsli, F.; Dihkan, M.; Acar, H.; Ozturk, A. Automatic Building Extraction from Very High-Resolution Image and LiDAR Data with SVM Algorithm. Arab. J. Geosci. 2016, 9, 635. [Google Scholar] [CrossRef] [Scilit]
- Niemeyer, J.; Rottensteiner, F.; Soergel, U. Contextual Classification of Lidar Data and Building Object Detection in Urban Areas. ISPRS J. Photogramm. Remote Sens. 2014, 87, 152–165. [Google Scholar] [CrossRef] [Scilit]
- Golovinskiy, A.; Kim, V.G.; Funkhouser, T. Shape-Based Recognition of 3D Point Clouds in Urban Environments. In Proceedings of the 2009 IEEE 12th International Conference on Computer Vision, Kyoto, Japan, 29 September–2 October 2009; pp. 2154–2161. [Google Scholar]
- Yao, W.; Wei, Y. Detection of 3-D Individual Trees in Urban Areas by Combining Airborne LiDAR Data and Imagery. IEEE Geosci. Remote Sens. Lett. 2013, 10, 1355–1359. [Google Scholar] [CrossRef] [Scilit]
- Zhao, H.; Liu, Y.; Zhu, X.; Zhao, Y.; Zha, H. Scene Understanding in a Large Dynamic Environment through a Laser-Based Sensing. In Proceedings of the 2010 IEEE International Conference on Robotics and Automation, Anchorage, AK, USA, 3–7 May 2010; pp. 127–133. [Google Scholar]
- Wang, H.; Wang, C.; Luo, H.; Li, P.; Cheng, M.; Wen, C.; Li, J. Object Detection in Terrestrial Laser Scanning Point Clouds Based on Hough Forest. IEEE Geosci. Remote Sens. Lett. 2014, 11, 1807–1811. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z.; Zhang, L.; Fang, T.; Mathiopoulos, P.T.; Tong, X.; Qu, H.; Xiao, Z.; Li, F.; Chen, D. A Multiscale and Hierarchical Feature Extraction Method for Terrestrial Laser Scanning Point Cloud Classification. IEEE Trans. Geosci. Remote Sens. 2015, 53, 2409–2425. [Google Scholar] [CrossRef] [Scilit]
- Zeng, A.; Yu, K.-T.; Song, S.; Suo, D.; Walker, E.; Rodriguez, A.; Xiao, J. Multi-View Self-Supervised Deep Learning for 6D Pose Estimation in the Amazon Picking Challenge. In Proceedings of the 2017 IEEE International Conference on Robotics and Automation, Singapore, 29 May–3 June 2017; p. 1386. [Google Scholar]
- Li, Z.; Gan, Y.; Liang, X.; Yu, Y.; Cheng, H.; Lin, L. LSTM-CF: Unifying Context Modeling and Fusion with LSTMs for RGB-D Scene Labeling. In Proceedings of the European Conference on Computer Vision, Amsterdam, The Netherlands, 11–14 October 2016; pp. 541–557. [Google Scholar]
- Lawin, F.J.; Danelljan, M.; Tosteberg, P.; Bhat, G.; Khan, F.S.; Felsberg, M. Deep Projective 3D Semantic Segmentation. In Proceedings of the Computer Analysis of Images and Patterns, Ystad, Sweden, 22–24 August 2017; pp. 95–107. [Google Scholar]
- Zhang, Z.; Cui, Z.; Xu, C.; Jie, Z.; Li, X.; Yang, J. Joint Task-Recursive Learning for Semantic Segmentation and Depth Estimation. In Proceedings of the European Conference on Computer Vision, Munich, Germany, 8–14 September 2018; pp. 235–251. [Google Scholar]
- Chen, Y.; Yang, M.; Wang, C.; Wang, B. 3D Semantic Modelling with Label Correction For Extensive Outdoor Scene. In Proceedings of the 2019 IEEE Intelligent Vehicles Symposium, Paris, France, 9–12 June 2019; pp. 1262–1267. [Google Scholar]
- Maturana, D.; Scherer, S. VoxNet: A 3D Convolutional Neural Network for Real-Time Object Recognition. In Proceedings of the 2015 IEEE/RSJ International Conference on Intelligent Robots and Systems, Hamburg, Germany, 28 September–2 October 2015; pp. 922–928. [Google Scholar]
- Chang, A.X.; Funkhouser, T.; Guibas, L. ShapeNet: An Information-Rich 3D Model Repository. arXiv 2015, arXiv:1512.03012. [Google Scholar]
- Wang, L.; Huang, Y.; Shan, J.; He, L. MSNet: Multi-Scale Convolutional Network for Point Cloud Classification. Remote Sens. 2018, 10, 612. [Google Scholar] [CrossRef] [Scilit]
- Roynard, X.; Deschaud, J.-E.; Goulette, F. Classification of Point Cloud Scenes with Multiscale Voxel Deep Network. arXiv 2018, arXiv:1804.03583. [Google Scholar]
- Qi, C.R. Deep Learning on Point Clouds for 3D Scene Understanding. Ph.D. Thesis, Standford University, Stanford, CA, USA, 2018. [Google Scholar]
- Qi, C.R.; Su, H.; Mo, K.; Guibas, L.J. PointNet: Deep Learning on Point Sets for 3D Classification and Segmentation. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Honolulu, HI, USA, 21–26 July 2017; pp. 652–660. [Google Scholar]
- Qi, C.R.; Yi, L.; Su, H.; Guibas, L.J. PointNet++: Deep Hierarchical Feature Learning on Point Sets in a Metric Space. In Proceedings of the Advances in Neural Information Processing Systems, Long Beach, CA, USA, 4–9 December 2017. [Google Scholar]
- Jiang, M.; Wu, Y.; Zhao, T.; Zhao, Z.; Lu, C. PointSIFT: A SIFT-like Network Module for 3D Point Cloud Semantic Segmentation. arXiv 2018, arXiv:1807.00652. [Google Scholar]
- Zhao, H.; Jiang, L.; Fu, C.-W.; Jia, J. PointWeb: Enhancing Local Neighborhood Features for Point Cloud Processing. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Long Beach, CA, USA, 15–20 June 2019; pp. 5565–5573. [Google Scholar]
- Wang, Y.; Sun, Y.; Liu, Z.; Sarma, S.E.; Bronstein, M.M.; Solomon, J.M. Dynamic Graph CNN for Learning on Point Clouds. ACM Trans. Graph. 2019, 38, 1–12. [Google Scholar] [CrossRef] [Scilit]
- Hu, Q.; Yang, B.; Xie, L.; Rosa, S.; Guo, Y.; Wang, Z.; Trigoni, N.; Markham, A. RandLA-Net: Efficient Semantic Segmentation of Large-Scale Point Clouds. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Seattle, WA, USA, 13–19 June 2020; pp. 11108–11117. [Google Scholar]
- Ren, D.; Li, J.; Wu, Z.; Guo, J.; Wei, M.; Guo, Y. MFFNet: Multimodal Feature Fusion Network for Point Cloud Semantic Segmentation. Vis. Comput. 2024, 40, 5155–5167. [Google Scholar] [CrossRef] [Scilit]
- Poliyapram, V.; Wang, W.; Nakamura, R. A Point-Wise LiDAR and Image Multimodal Fusion Network (PMNet) for Aerial Point Cloud 3D Semantic Segmentation. Remote Sens. 2019, 11, 2961. [Google Scholar] [CrossRef] [Scilit]
- Peng, J.; Cui, Y.; Zhong, Z.; An, Y. Ore Rock Fragmentation Calculation Based on Multi-Modal Fusion of Point Clouds and Images. Appl. Sci. 2023, 13, 12558. [Google Scholar] [CrossRef] [Scilit]
- An, Y.; Liu, W.; Cui, Y.; Wang, J.; Li, X.; Hu, H. Multilevel Ground Segmentation for 3-D Point Clouds of Outdoor Scenes Based on Shape Analysis. IEEE Trans. Instrum. Meas. 2022, 71, 1–13. [Google Scholar] [CrossRef] [Scilit]
- Hu, X.; An, Y.; Shao, C.; Hu, H. Distortion Convolution Module for Semantic Segmentation of Panoramic Images Based on the Image-Forming Principle. IEEE Trans. Instrum. Meas. 2022, 71, 1–12. [Google Scholar] [CrossRef] [Scilit]
- Cui, Y.; Zhang, Z.; An, Y.; Zhong, Z.; Yang, F.; Wang, J.; He, K. Memory-Augmented 3D Point Cloud Semantic Segmentation Network for Intelligent Mining Shovels. Sensors 2024, 24, 4364. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Si, L.; Wang, Z.; Liu, P.; Tan, C.; Chen, H.; Wei, D. A Novel Coal–Rock Recognition Method for Coal Mining Working Face Based on Laser Point Cloud Data. IEEE Trans. Instrum. Meas. 2021, 70, 1–18. [Google Scholar] [CrossRef] [Scilit]
- Guo, Q.; Wang, Y.; Yang, S.; Xiang, Z. A Method of Blasted Rock Image Segmentation Based on Improved Watershed Algorithm. Sci. Rep. 2022, 12, 7143. [Google Scholar] [CrossRef] [Scilit]
- Xiao, D.; Liu, X.; Le, B.T.; Ji, Z.; Sun, X. An Ore Image Segmentation Method Based on RDU-Net Model. Sensors 2020, 20, 4979. [Google Scholar] [CrossRef] [Scilit]
- Wang, F.; Jiang, M.; Qian, C.; Yang, S.; Li, C.; Zhang, H.; Wang, X.; Tang, X. Residual Attention Network for Image Classification. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Honolulu, HI, USA, 21–26 July 2017; pp. 3156–3164. [Google Scholar]
- Chen, L.; Zhang, H.; Xiao, J.; Nie, L.; Shao, J.; Liu, W.; Chua, T.-S. SCA-CNN: Spatial and Channel-Wise Attention in Convolutional Networks for Image Captioning. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Honolulu, HI, USA, 21–26 July 2017; pp. 5659–5667. [Google Scholar]
- Hu, J.; Shen, L.; Sun, G. Squeeze-and-Excitation Networks. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Salt Lake City, UT, USA, 18–23 June 2018; pp. 7132–7141. [Google Scholar]
- Woo, S.; Park, J.; Lee, J.-Y.; Kweon, I.S. CBAM: Convolutional Block Attention Module. In Proceedings of the European Conference on Computer Vision, Munich, Germany, 8–14 September 2018; pp. 3–19. [Google Scholar]
- Zhu, X.; Zhang, J.; Chen, G. ASAN: Self-Attending and Semantic Activating Network towards Better Object Detection. IEICE Trans. Inf. Syst. 2020, 103, 648–659. [Google Scholar] [CrossRef] [Scilit]
- Zeng, Y.; Ritz, C.; Zhao, J.; Lan, J. Attention-Based Residual Network with Scattering Transform Features for Hyperspectral Unmixing with Limited Training Samples. Remote Sens. 2020, 12, 400. [Google Scholar] [CrossRef] [Scilit]
- Chollet, F. Xception: Deep Learning with Depthwise Separable Convolutions. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Honolulu, HI, USA, 21–26 July 2017; pp. 1251–1258. [Google Scholar]
- Iandola, F.N.; Han, S.; Moskewicz, M.W.; Ashraf, K.; Dally, W.J.; Keutzer, K. SqueezeNet: AlexNet-Level Accuracy with 50x Fewer Parameters and <0.5MB Model Size. arXiv 2016, arXiv:1602.07360. [Google Scholar]
- Zhang, X.; Zhou, X.; Lin, M.; Sun, J. ShuffleNet: An Extremely Efficient Convolutional Neural Network for Mobile Devices. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Salt Lake City, UT, USA, 18–23 June 2018; pp. 6848–6856. [Google Scholar]
- Ma, N.; Zhang, X.; Zheng, H.-T.; Sun, J. ShuffleNet V2: Practical Guidelines for Efficient CNN Architecture Design. In Proceedings of the European Conference on Computer Vision, Munich, Germany, 8–14 September 2018; pp. 116–131. [Google Scholar]
- Howard, A.G.; Zhu, M.; Chen, B.; Kalenichenko, D.; Wang, W.; Weyand, T.; Andreetto, M.; Adam, H. MobileNets: Efficient Convolutional Neural Networks for Mobile Vision Application. Autom. Constr. 2020, 109, 102991. [Google Scholar]
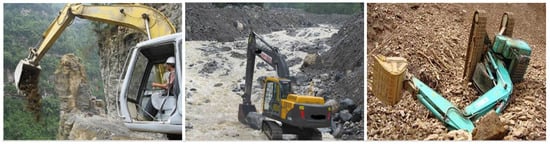
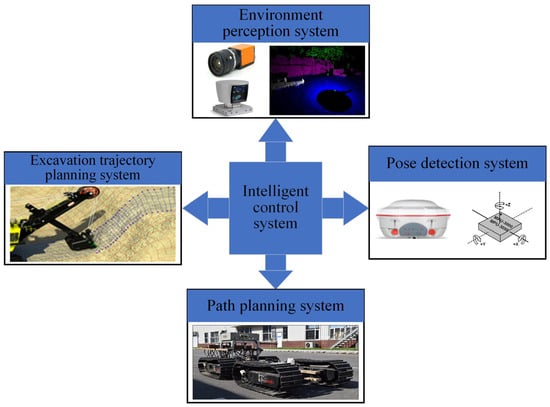
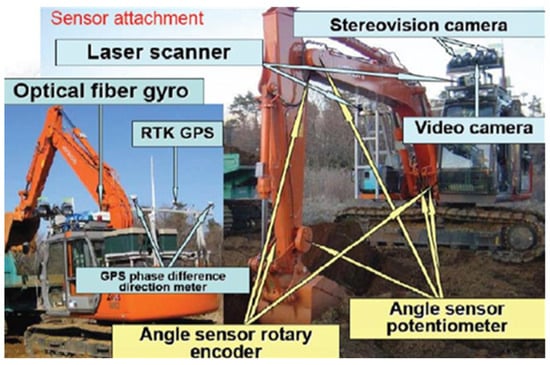
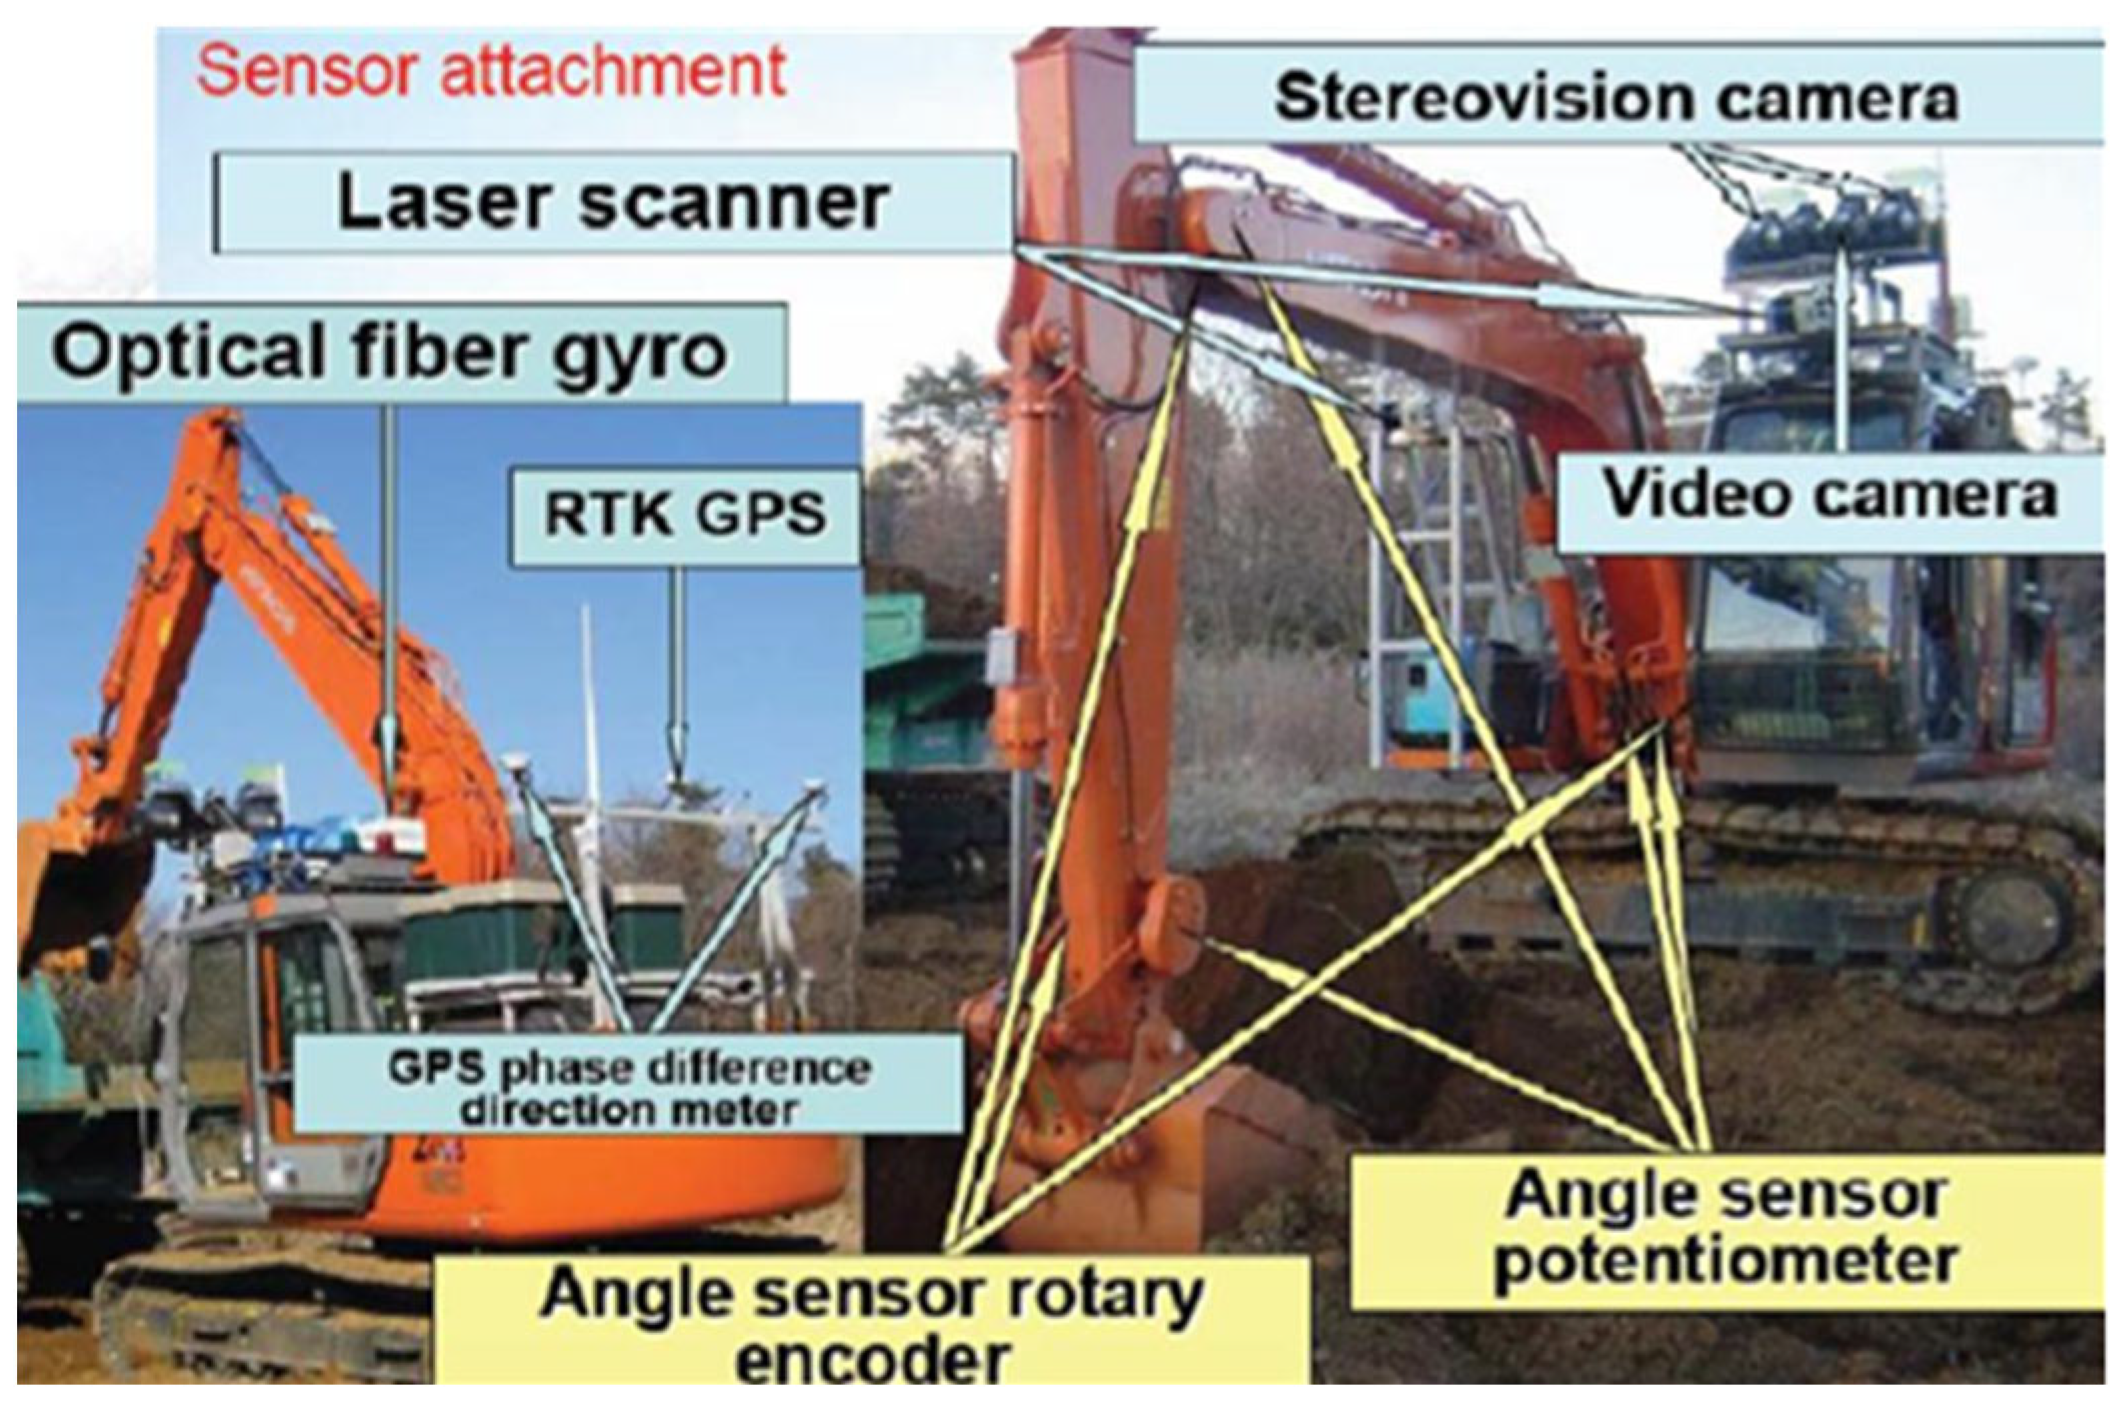
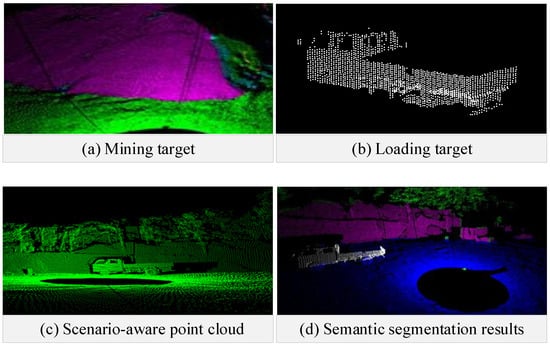
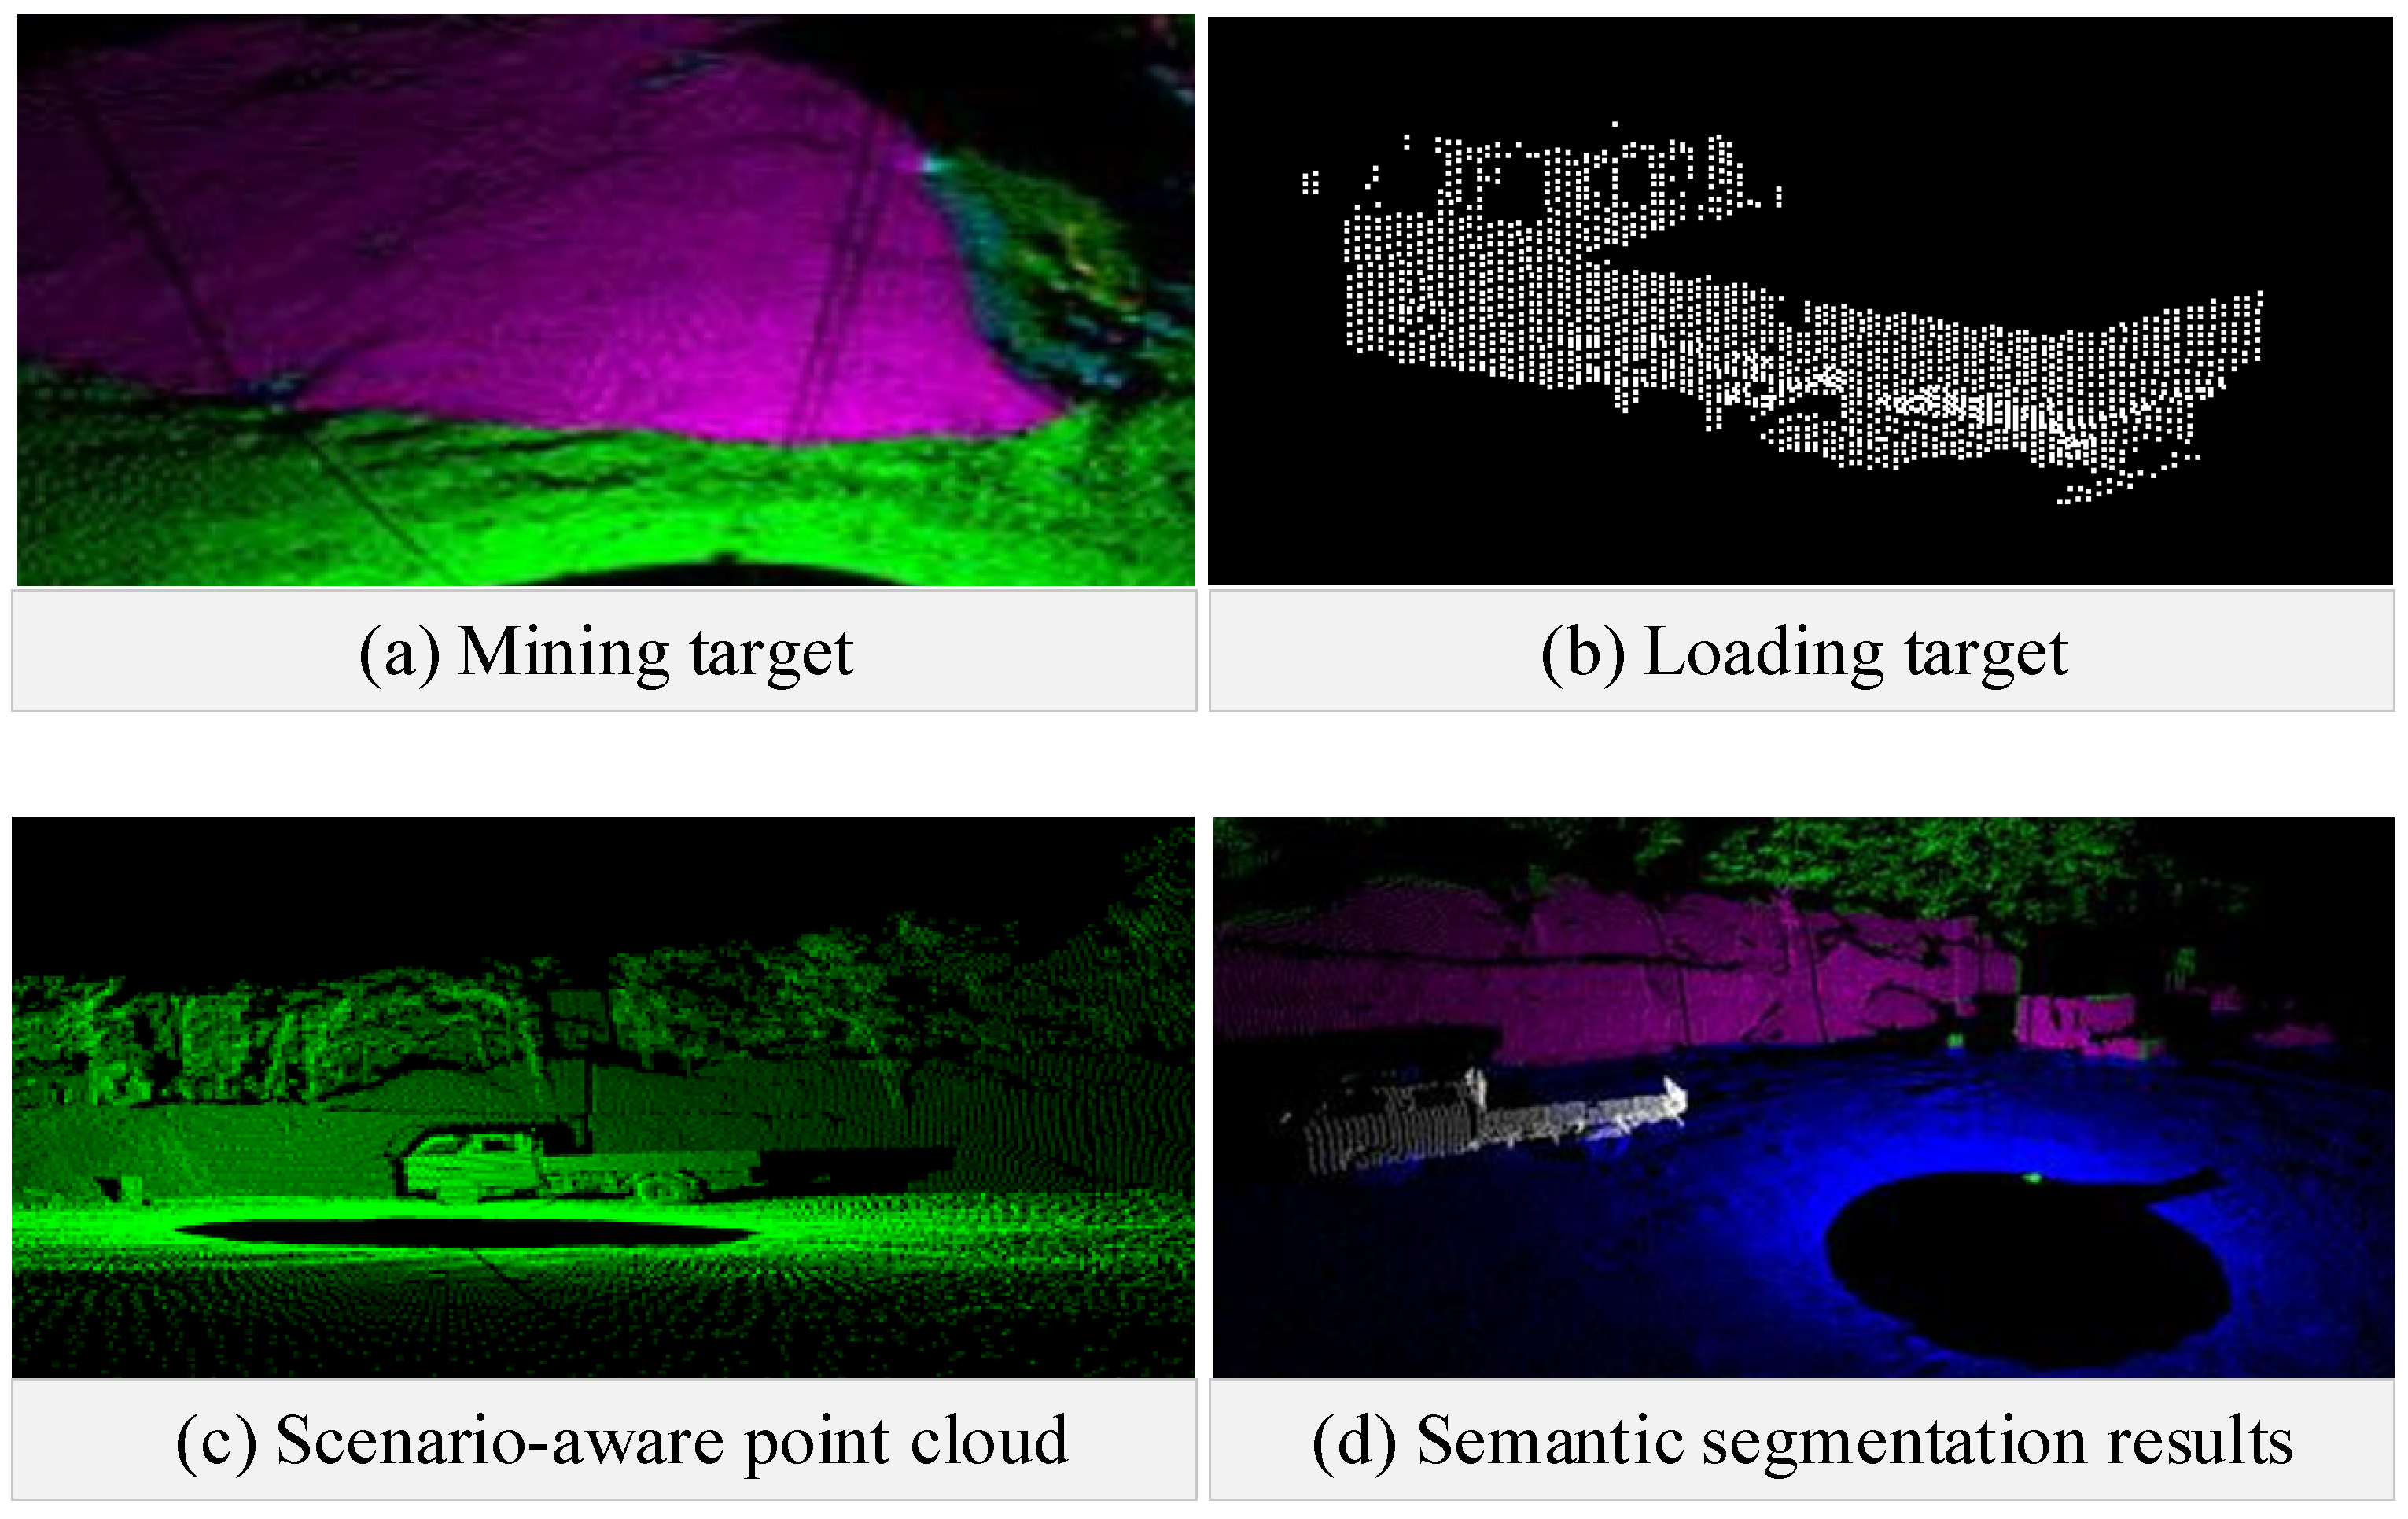
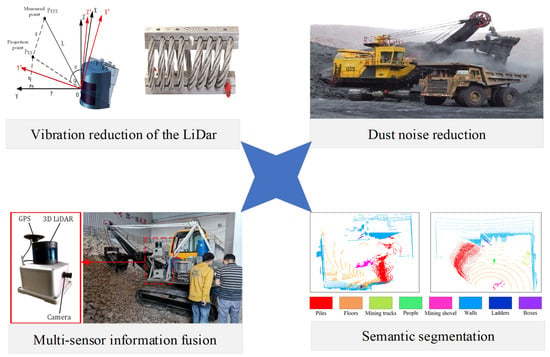
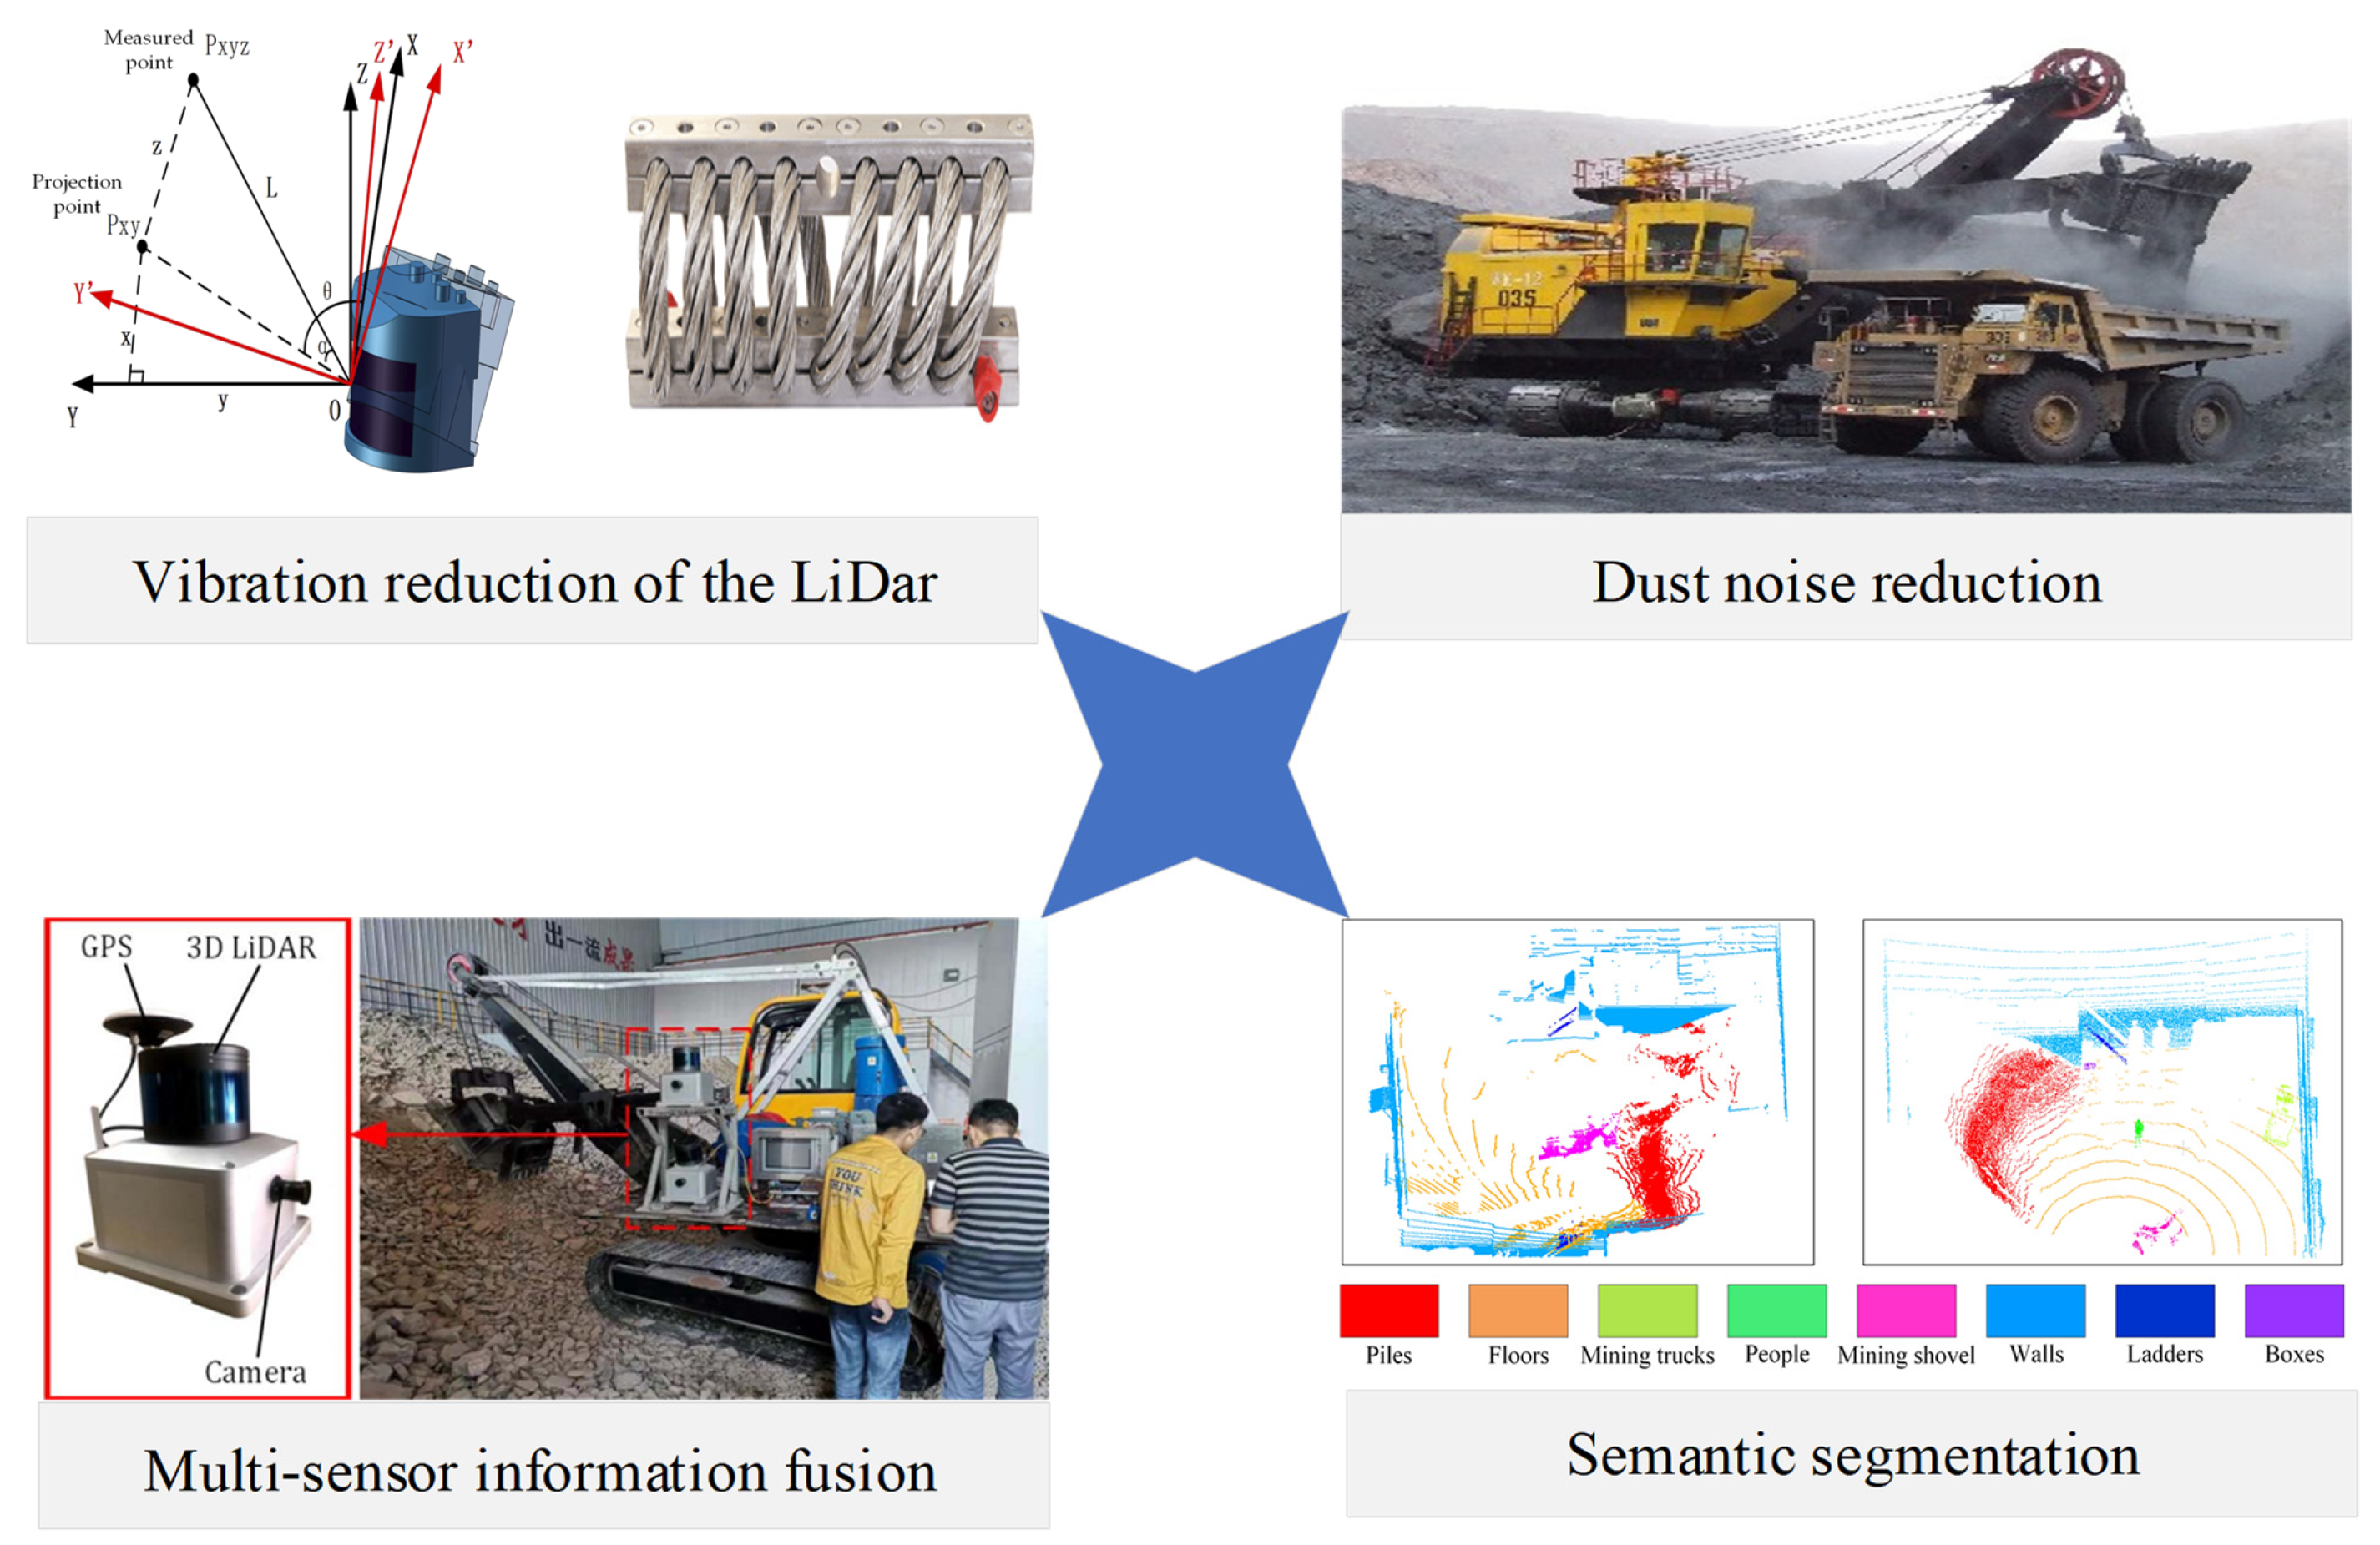

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).