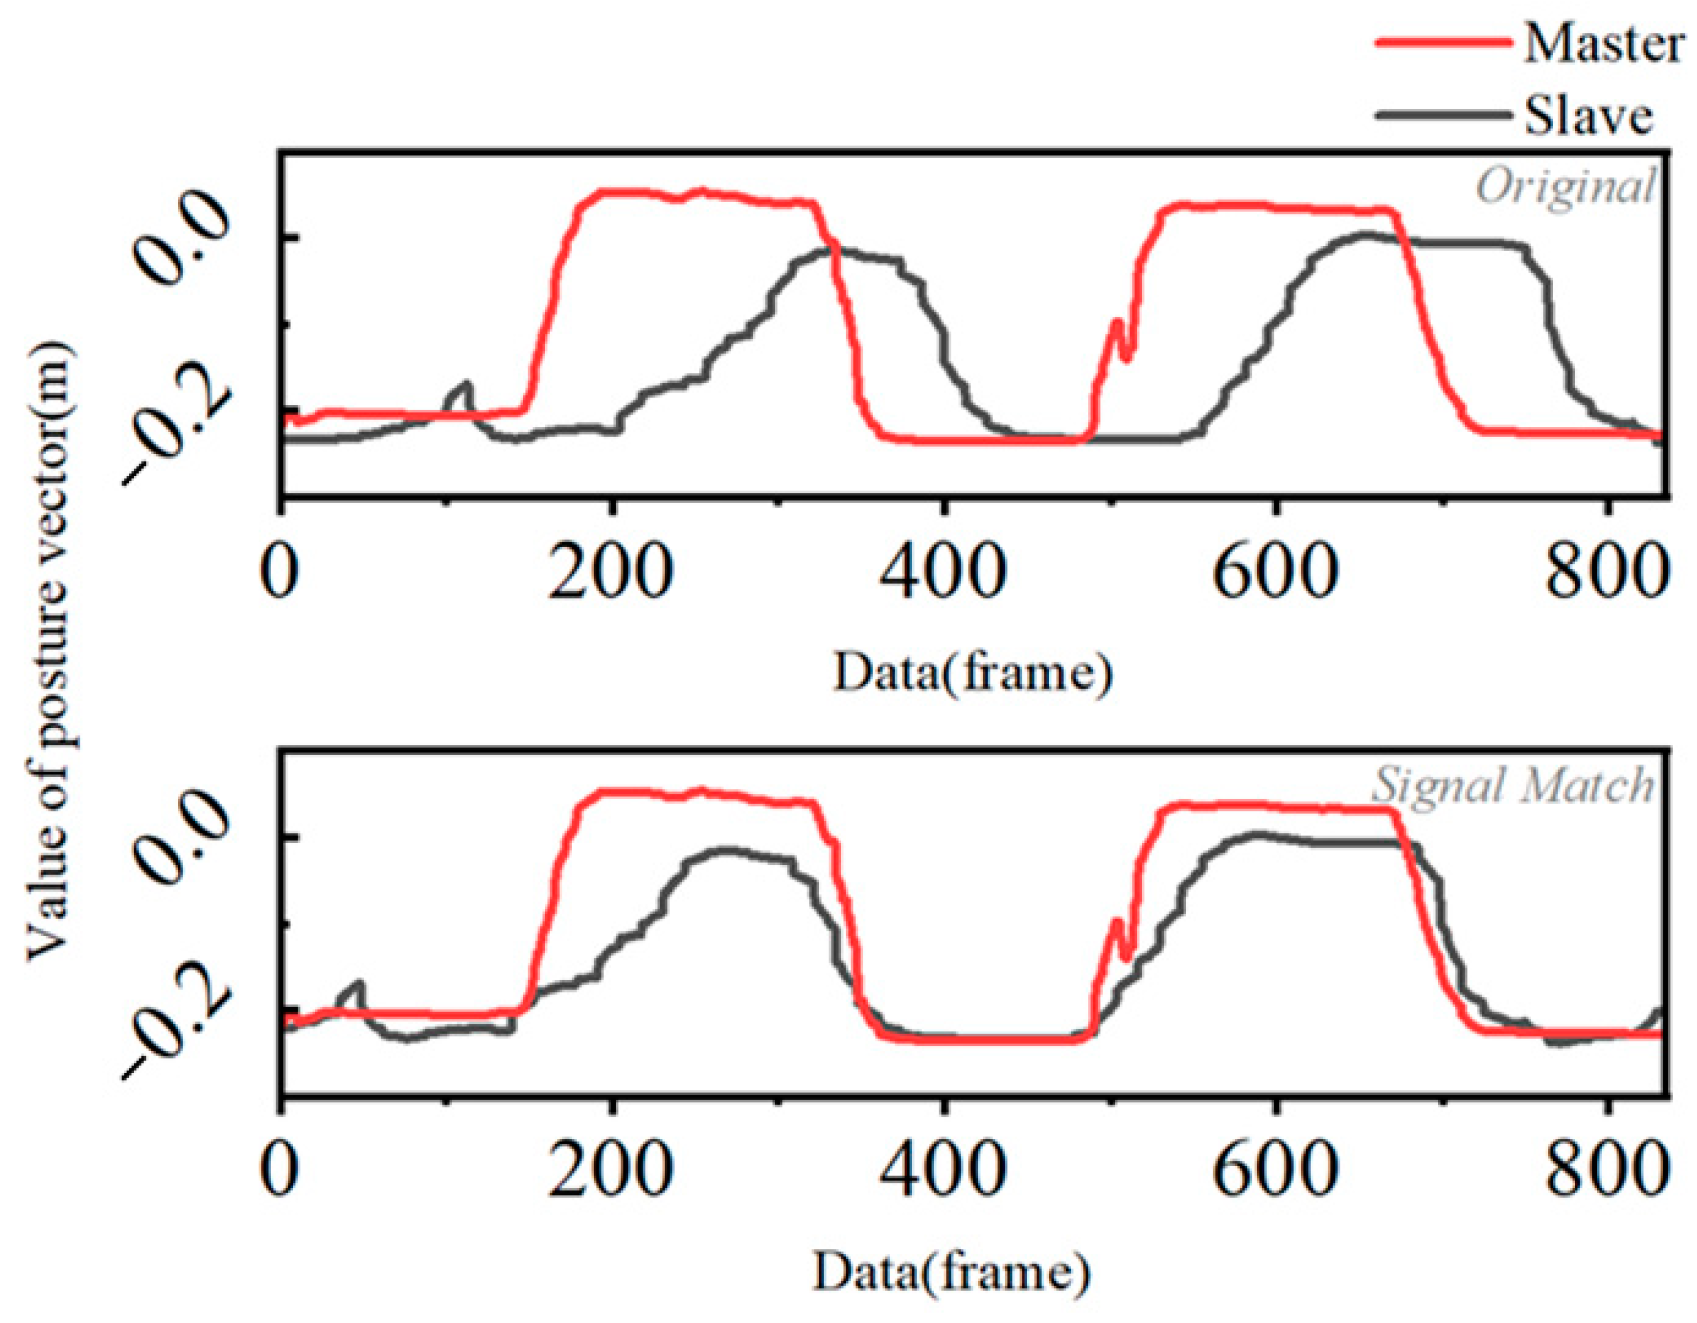
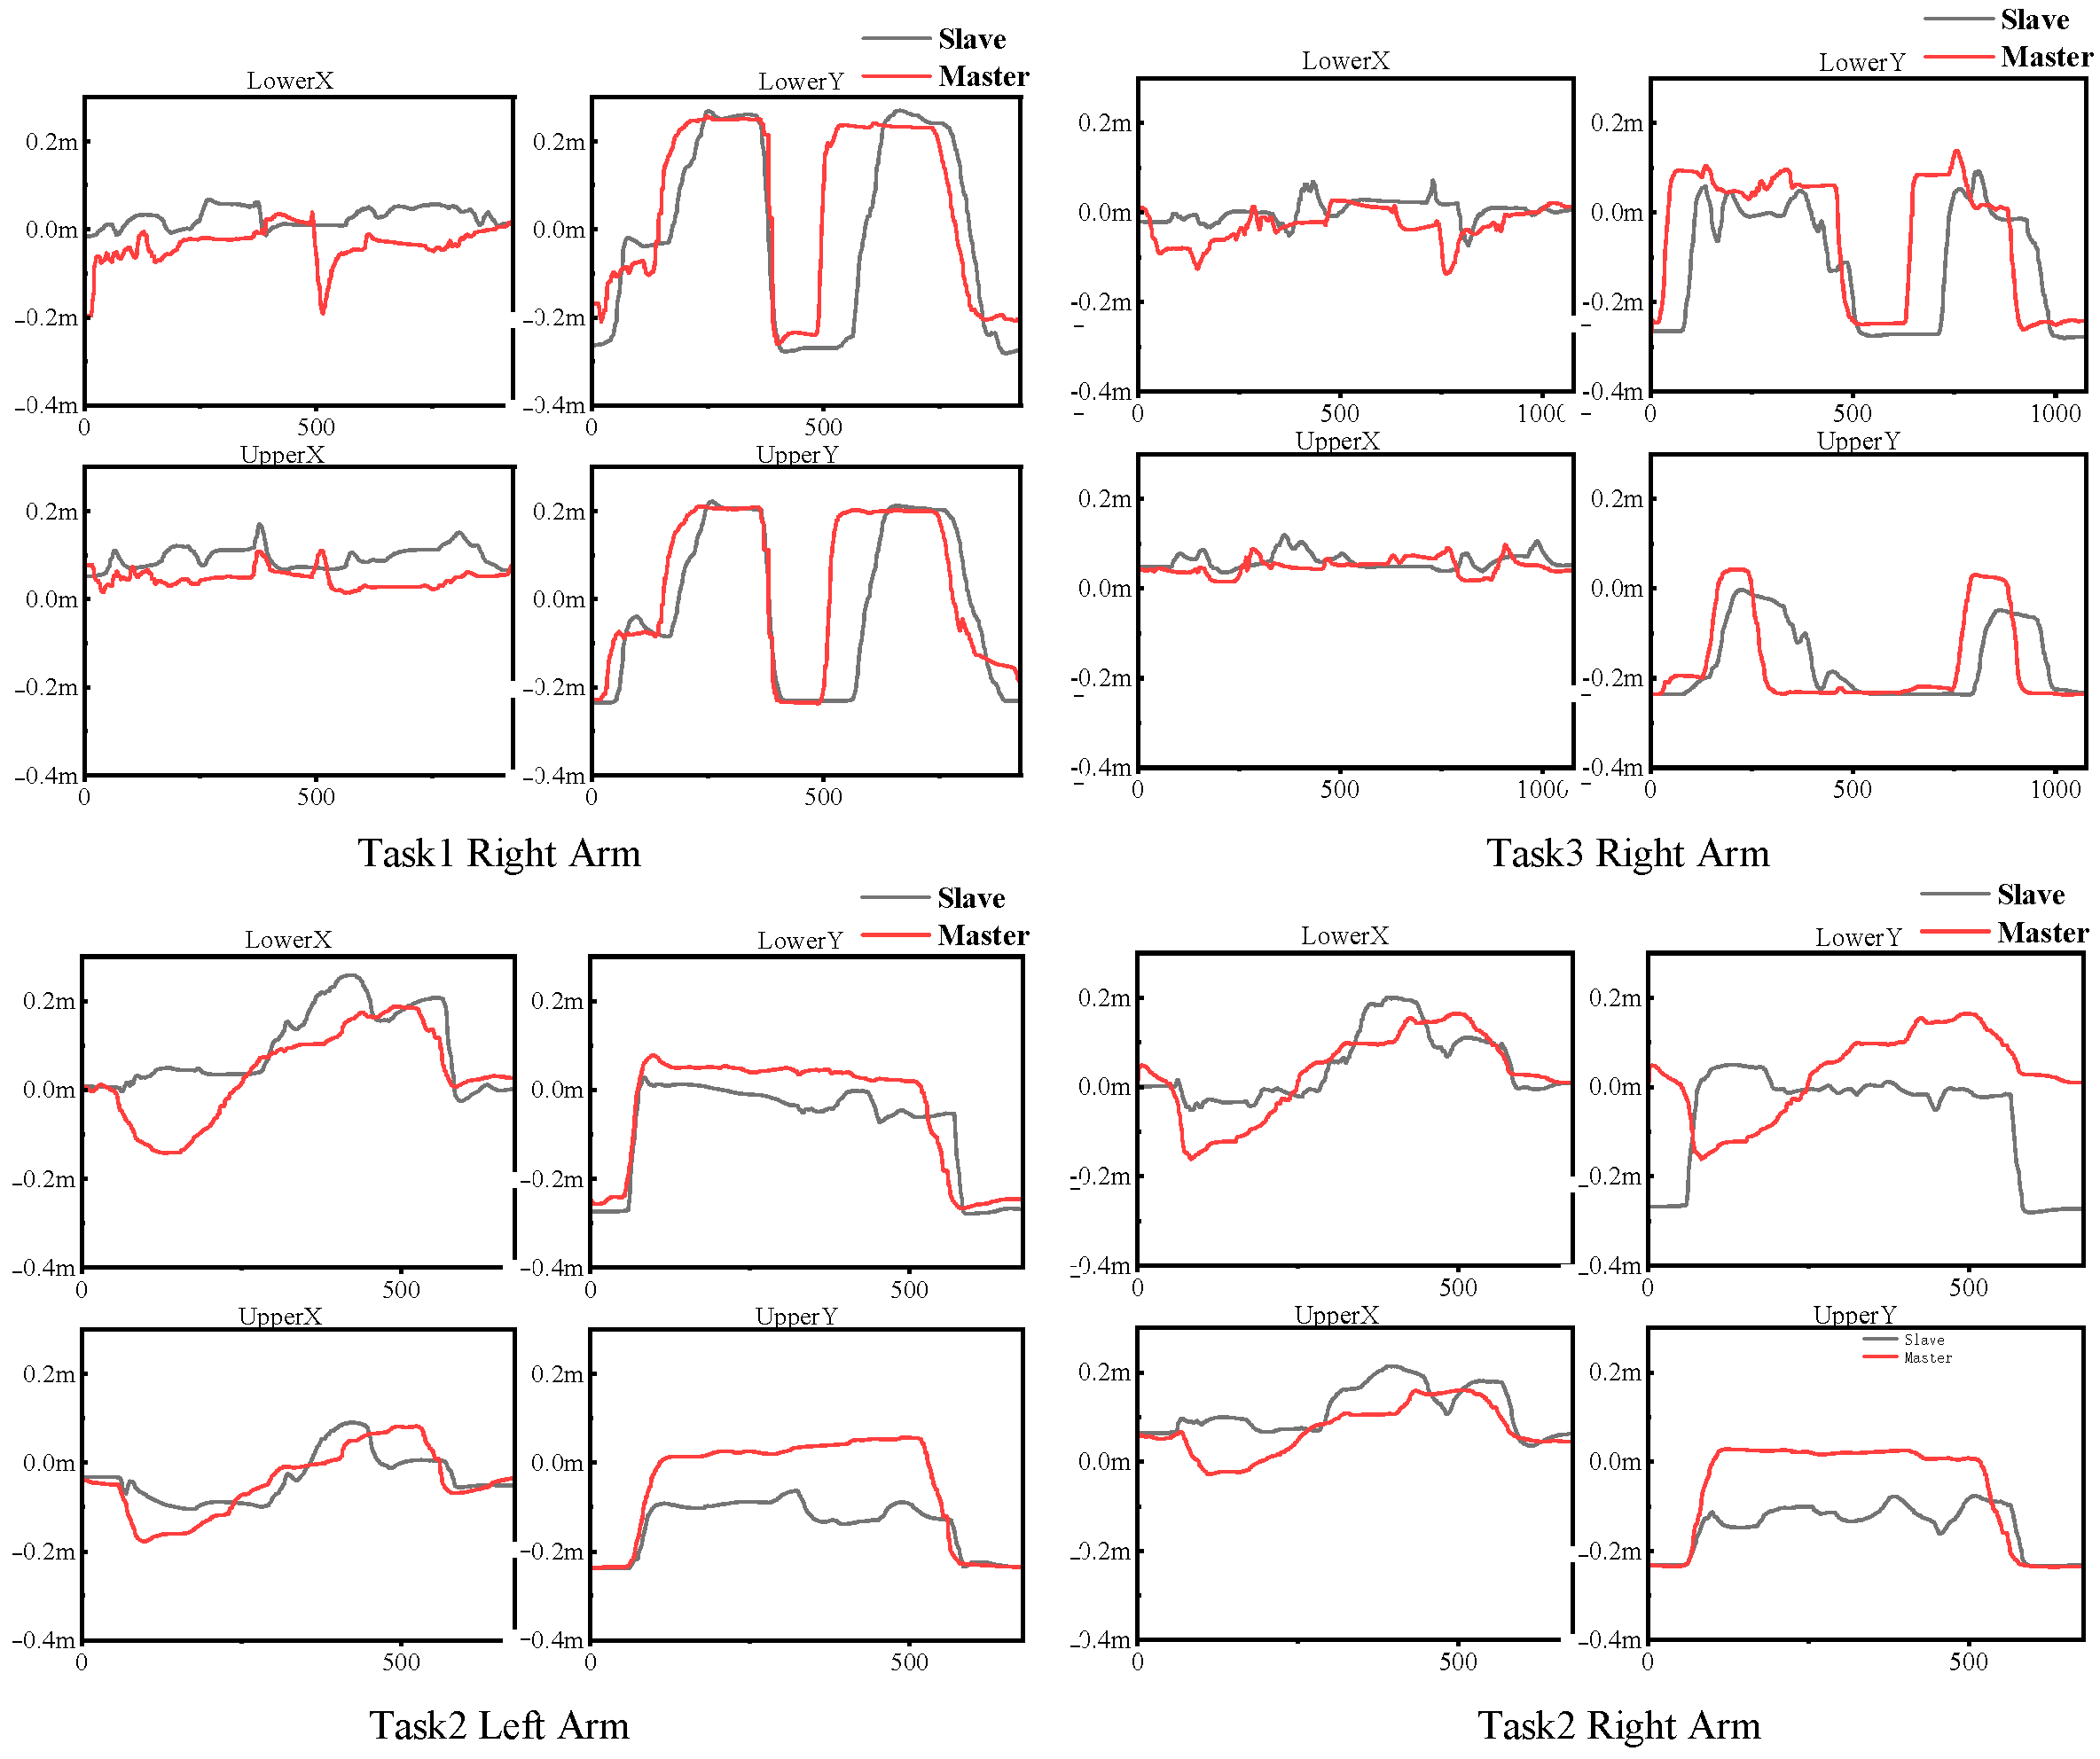
Vibrotactile-Based Operational Guidance System for Space Science Experiments
Abstract
1. Introduction
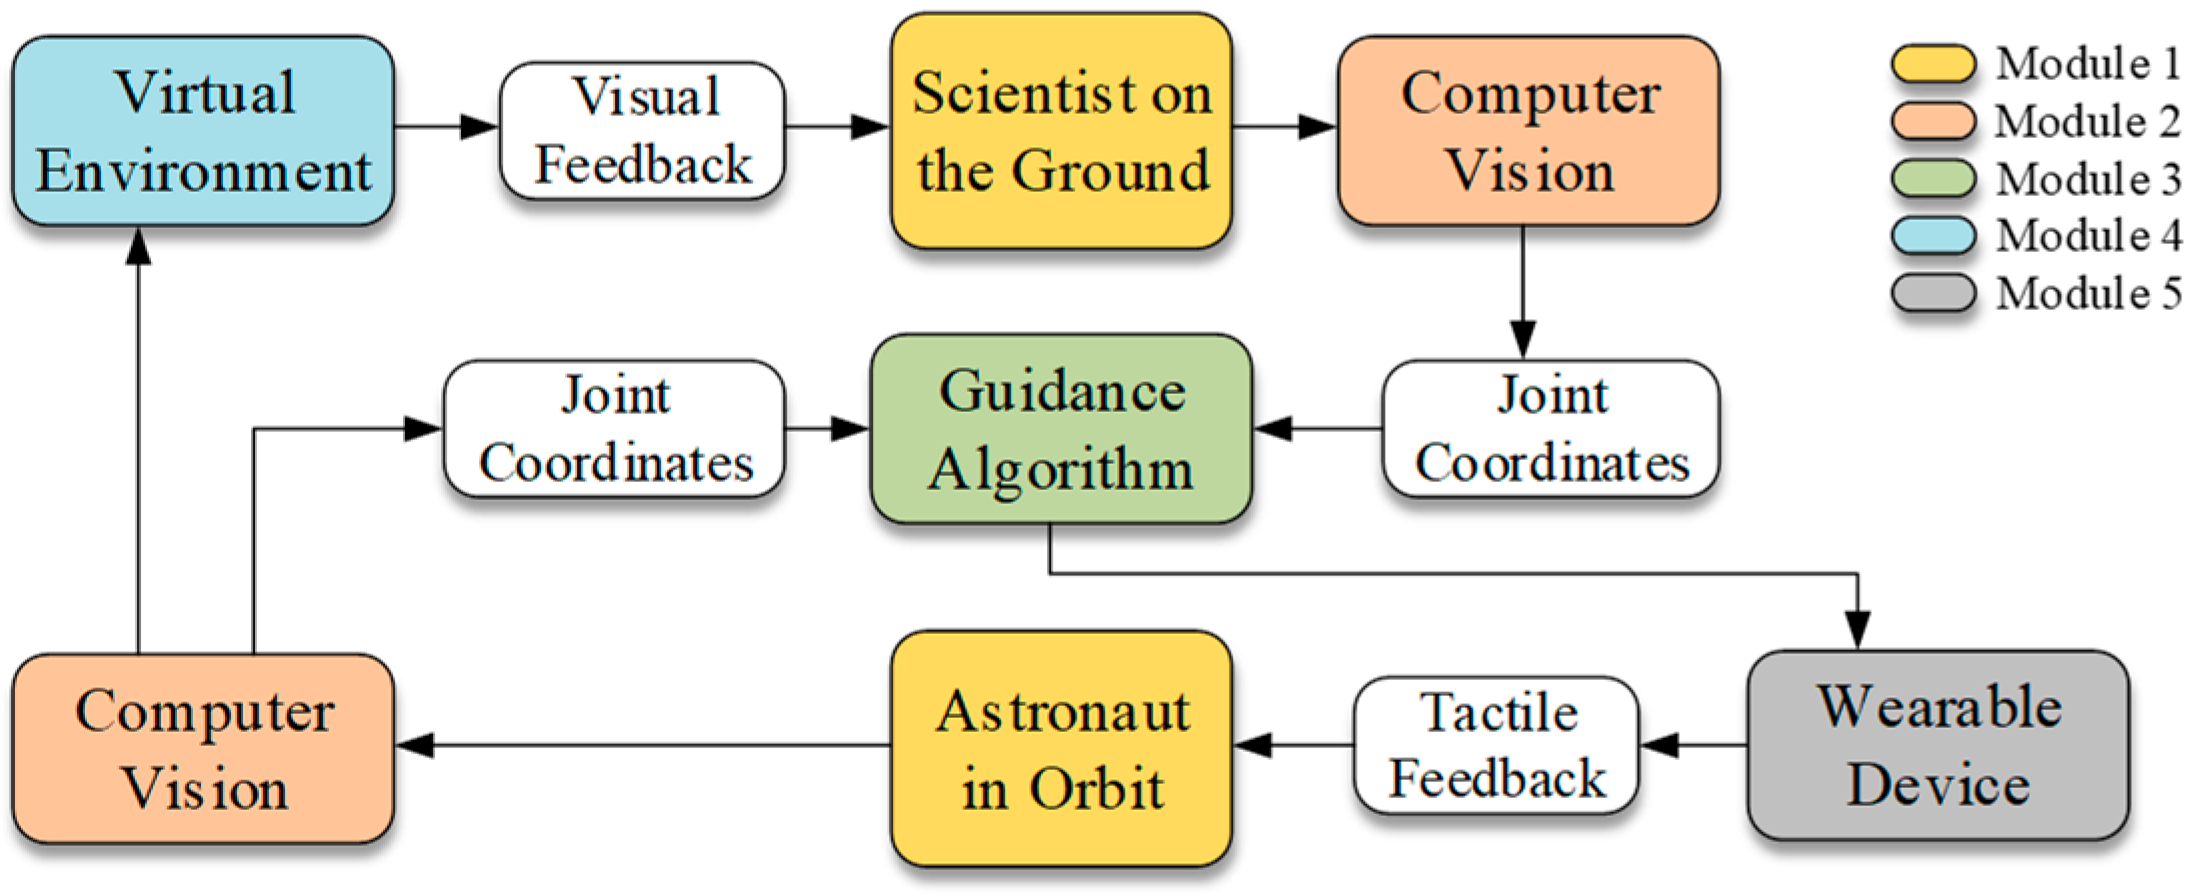
2. The Method of Operational Guidance
3. System Implementation
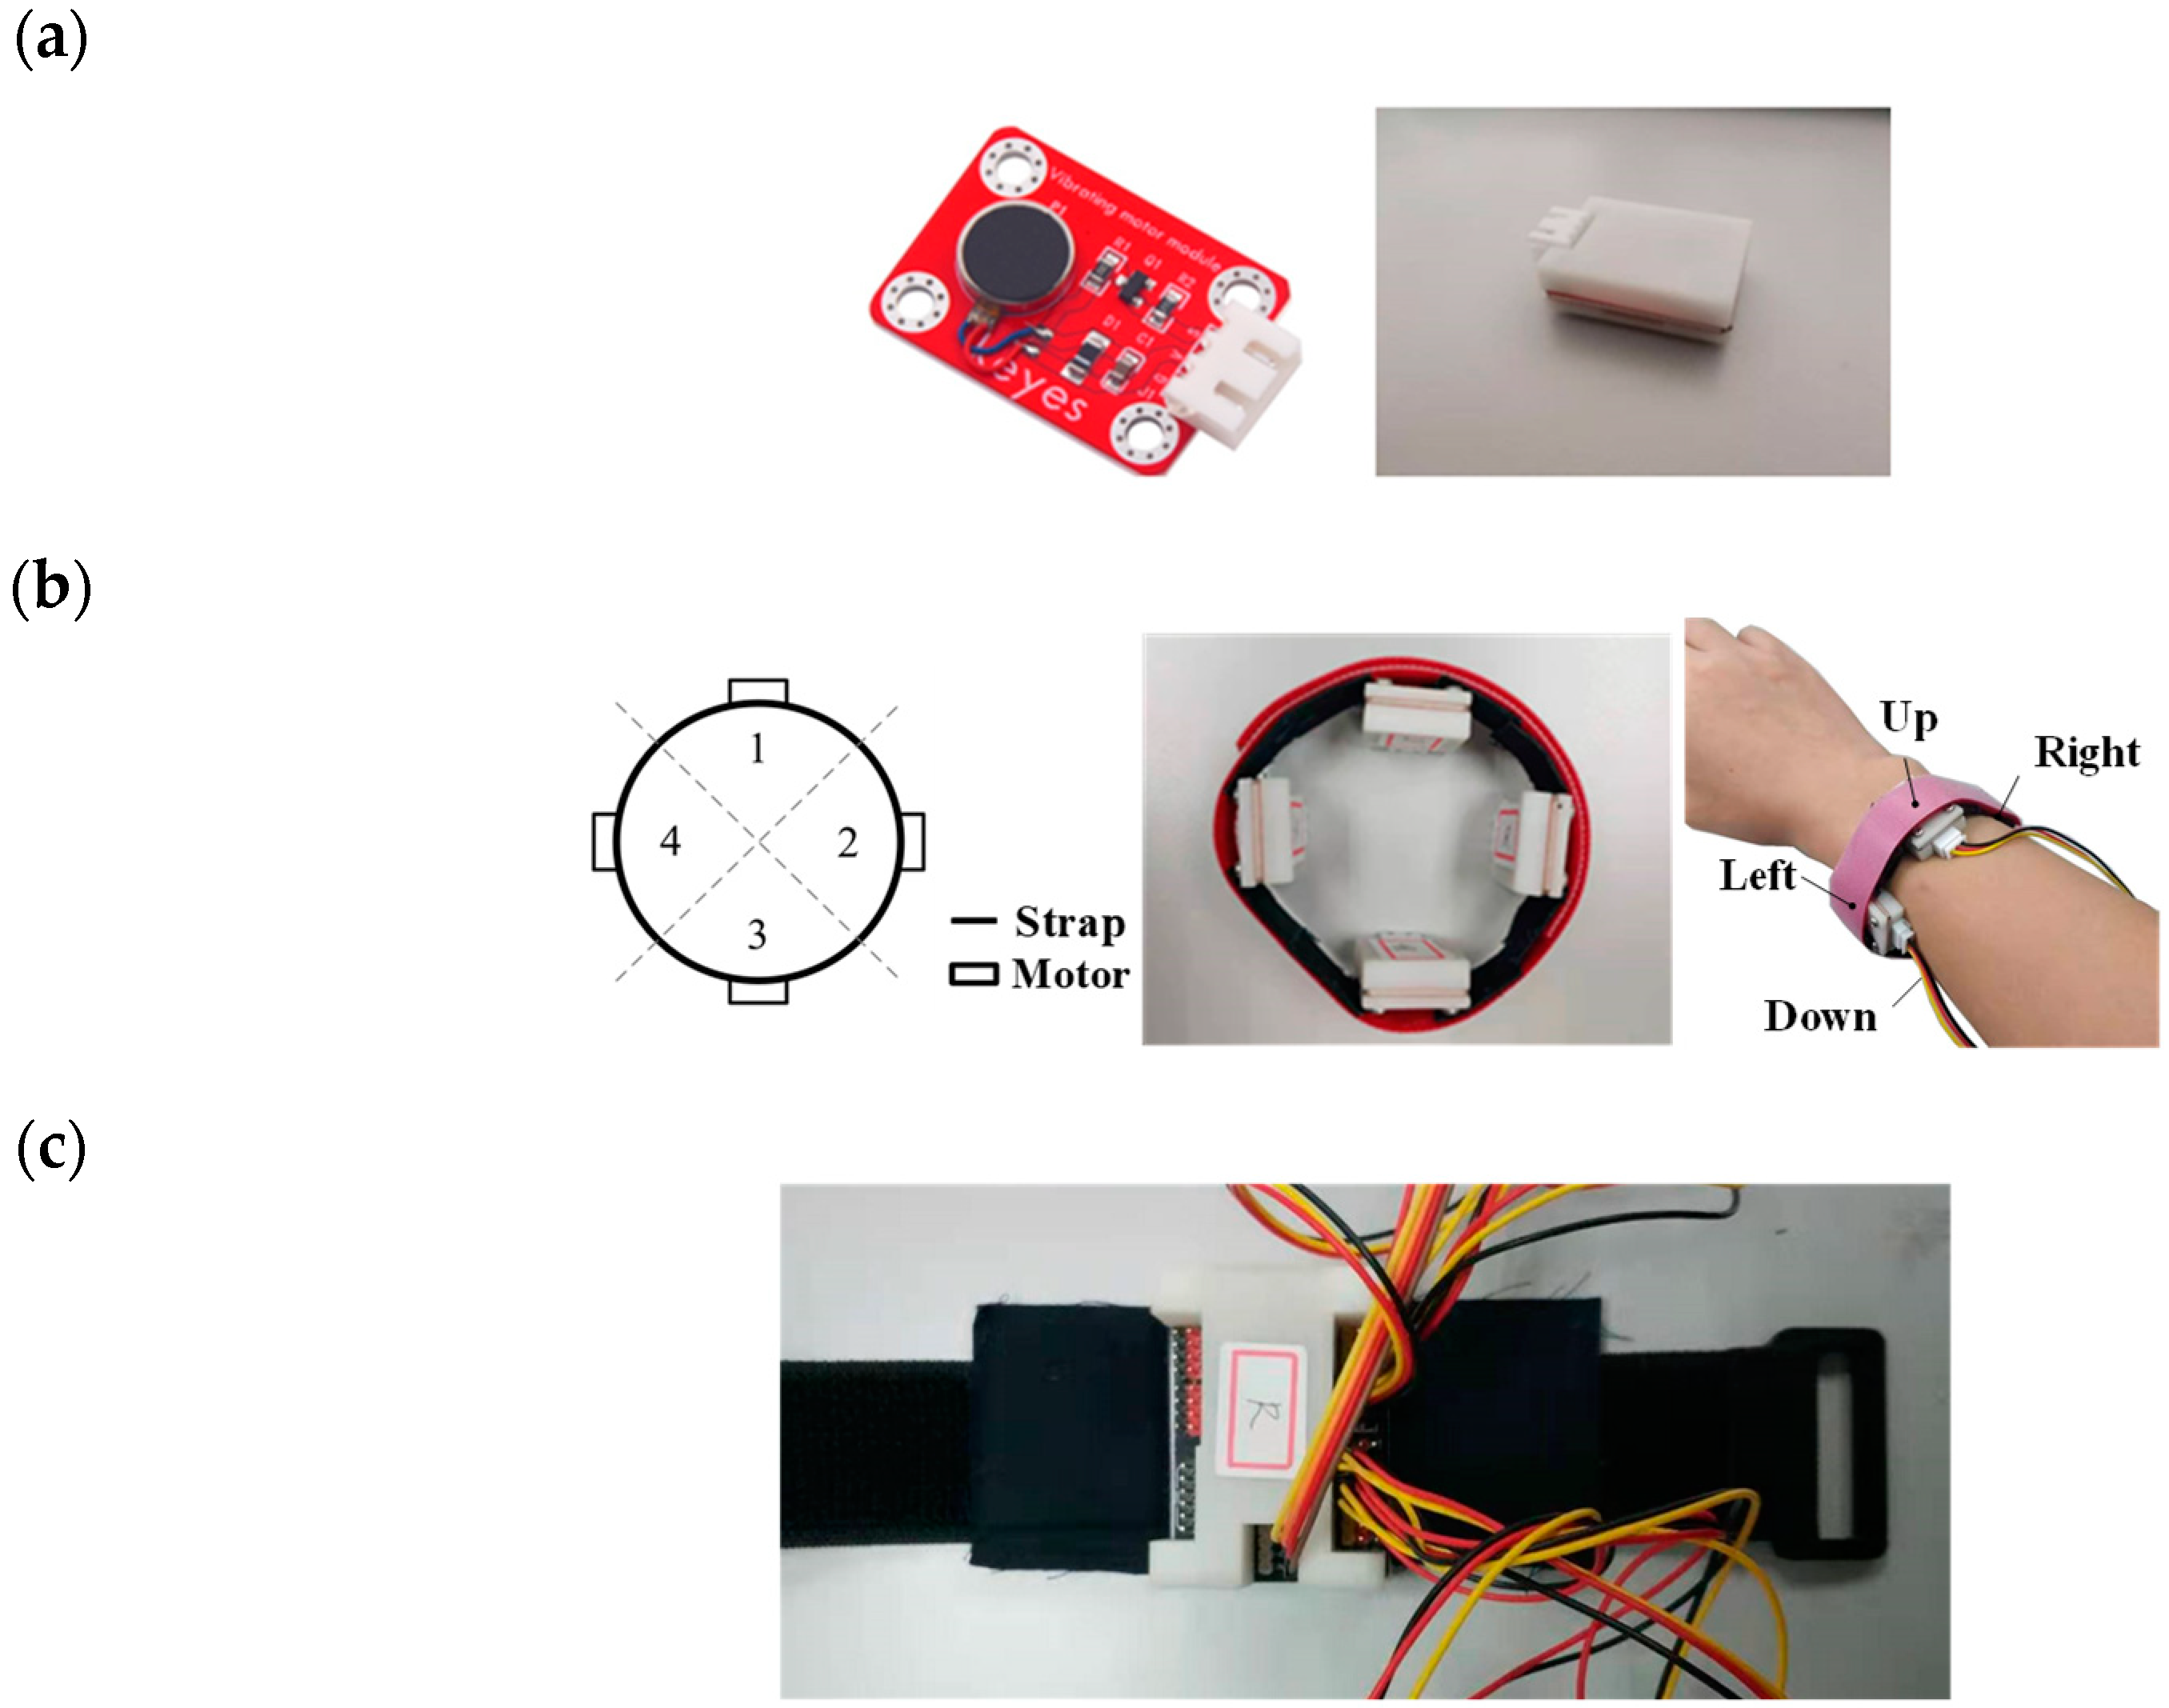
3.1. Wearable Device
3.2. Movements Capture, Data Processing
3.3. Guidance Algorithm
4. Experiments
4.1. Experiment 1: Perceptual Test
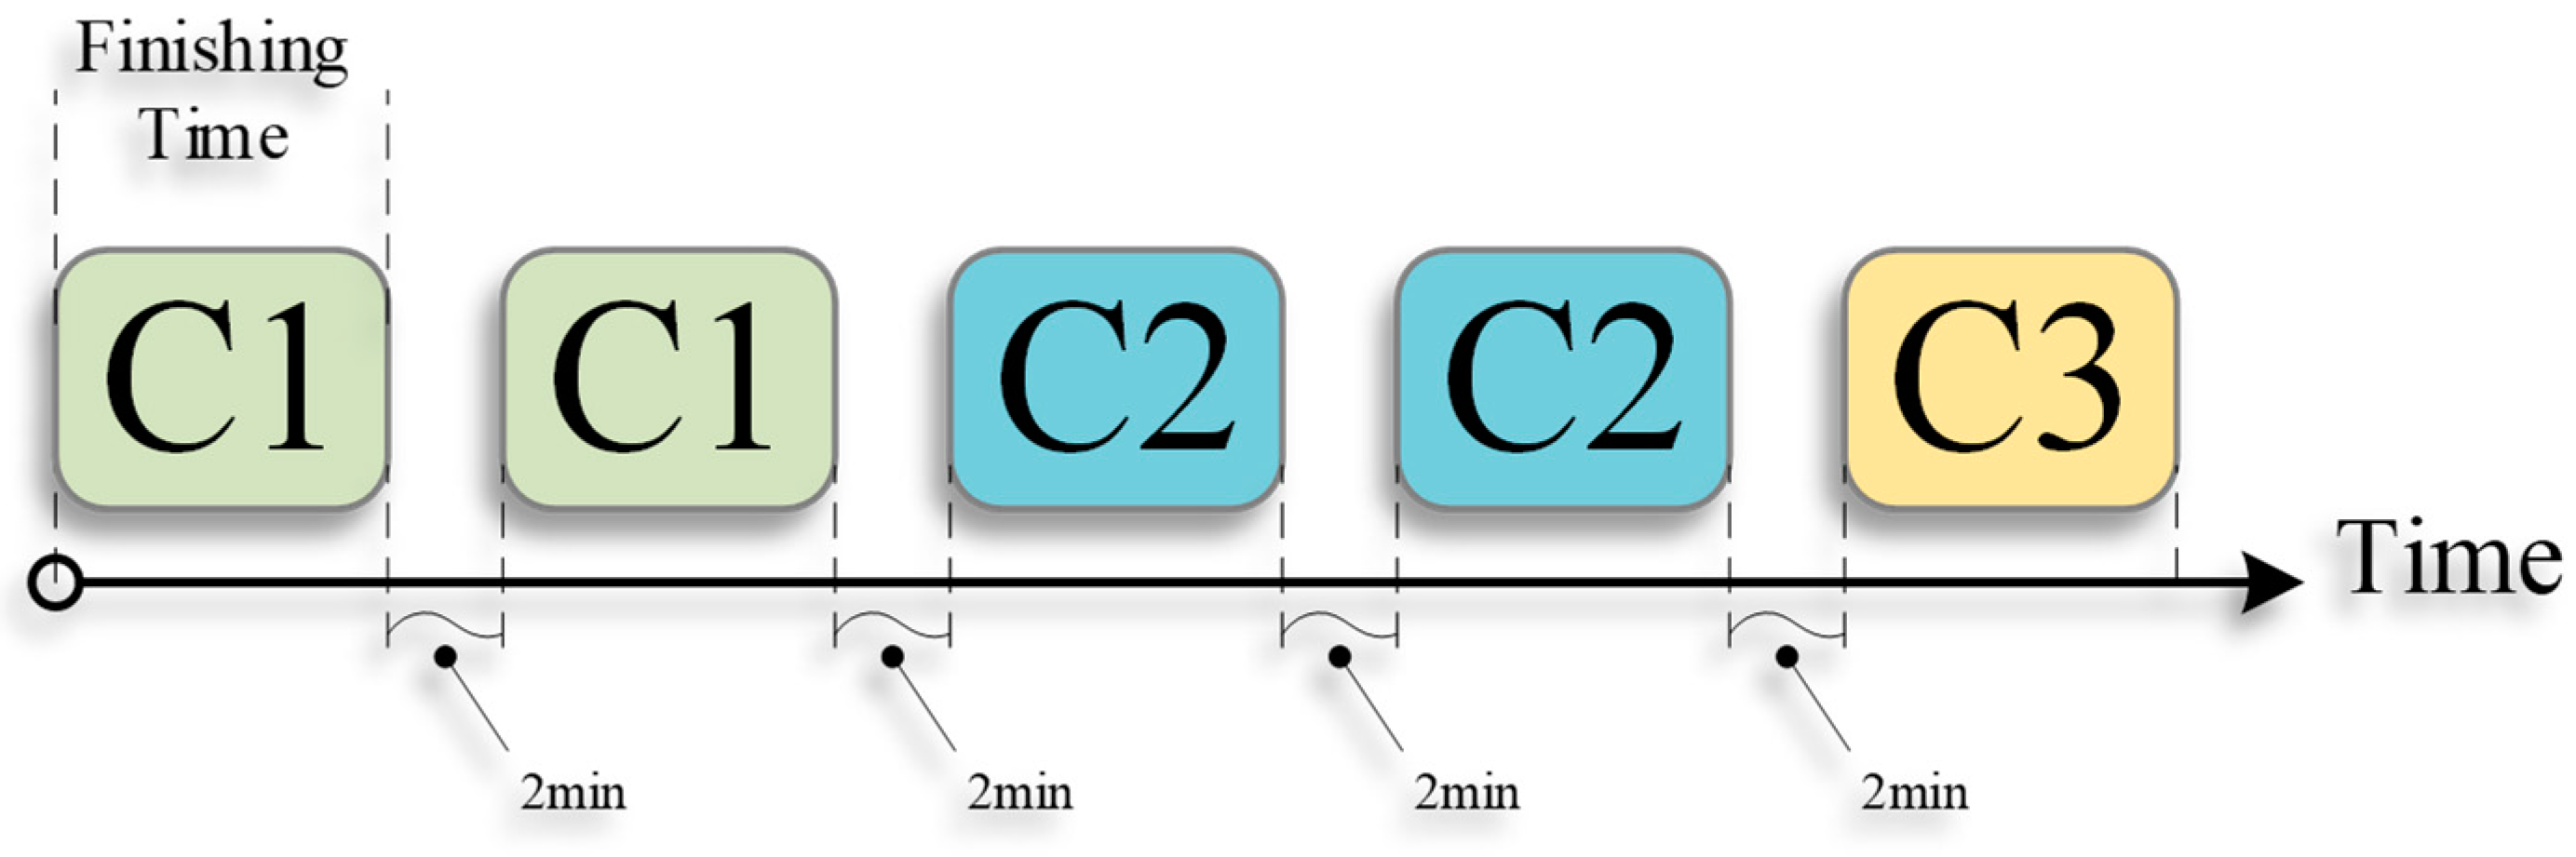
- C1: Using a single vibration source, we conducted 50 trials. For each trial, the wearable device generated a random vibrotactile stimulus;
- C2: Using two vibration sources, we conducted 50 trials, and for each trial, the wearable device randomly and simultaneously generated two vibrotactile stimuli at different positions;
- C3: Using four vibration sources, we conducted 10 trials, and for each trial, the wearable device generated four stimuli on the basis of predetermined order.
4.2. Experiment 2: Guiding Training
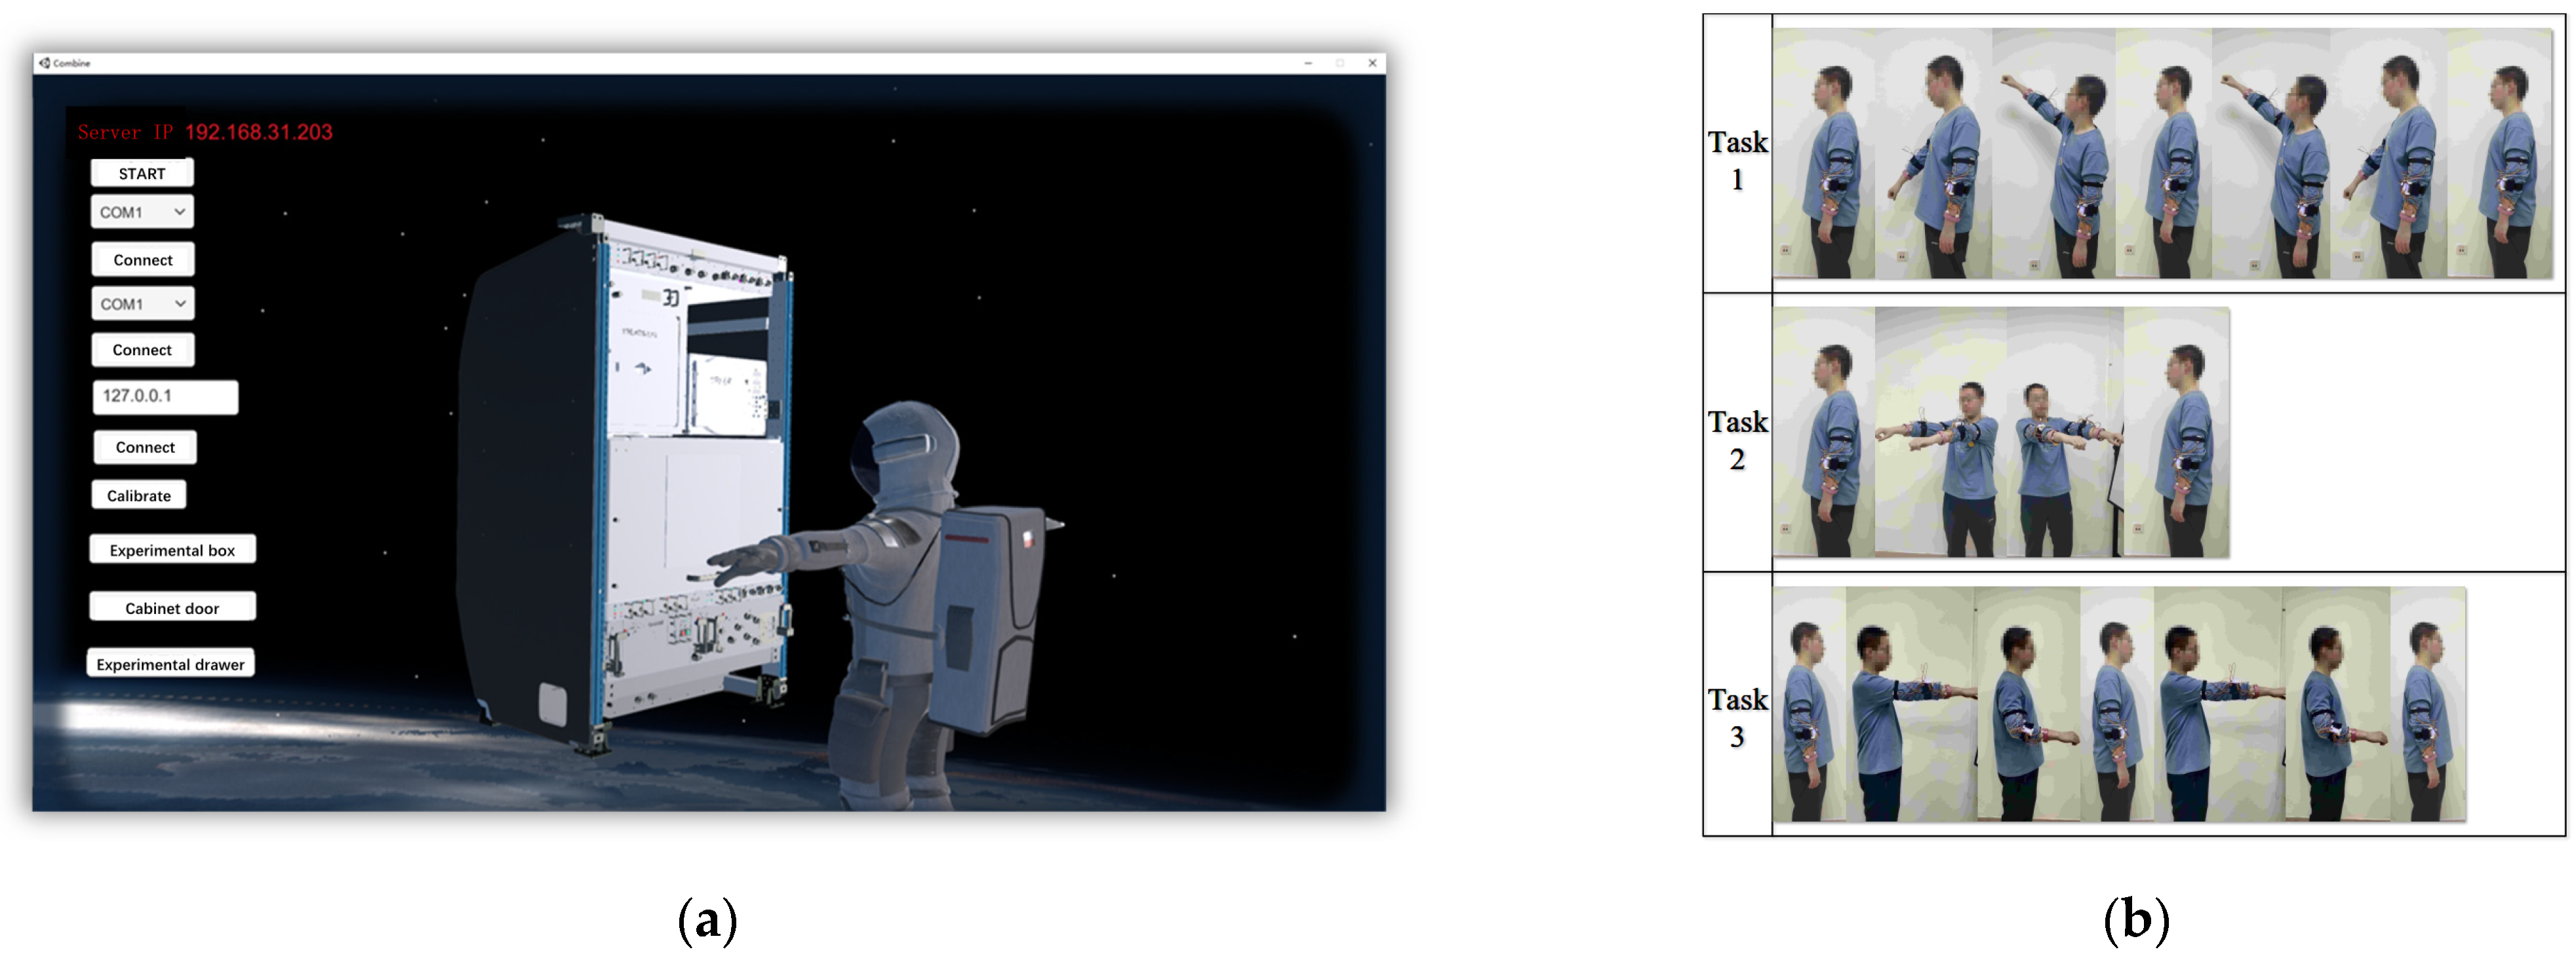
4.3. Experiment 3: Master–Slave Operational Guidance Experiment
5. Results and Discussion
5.1. Experiment 1: Results
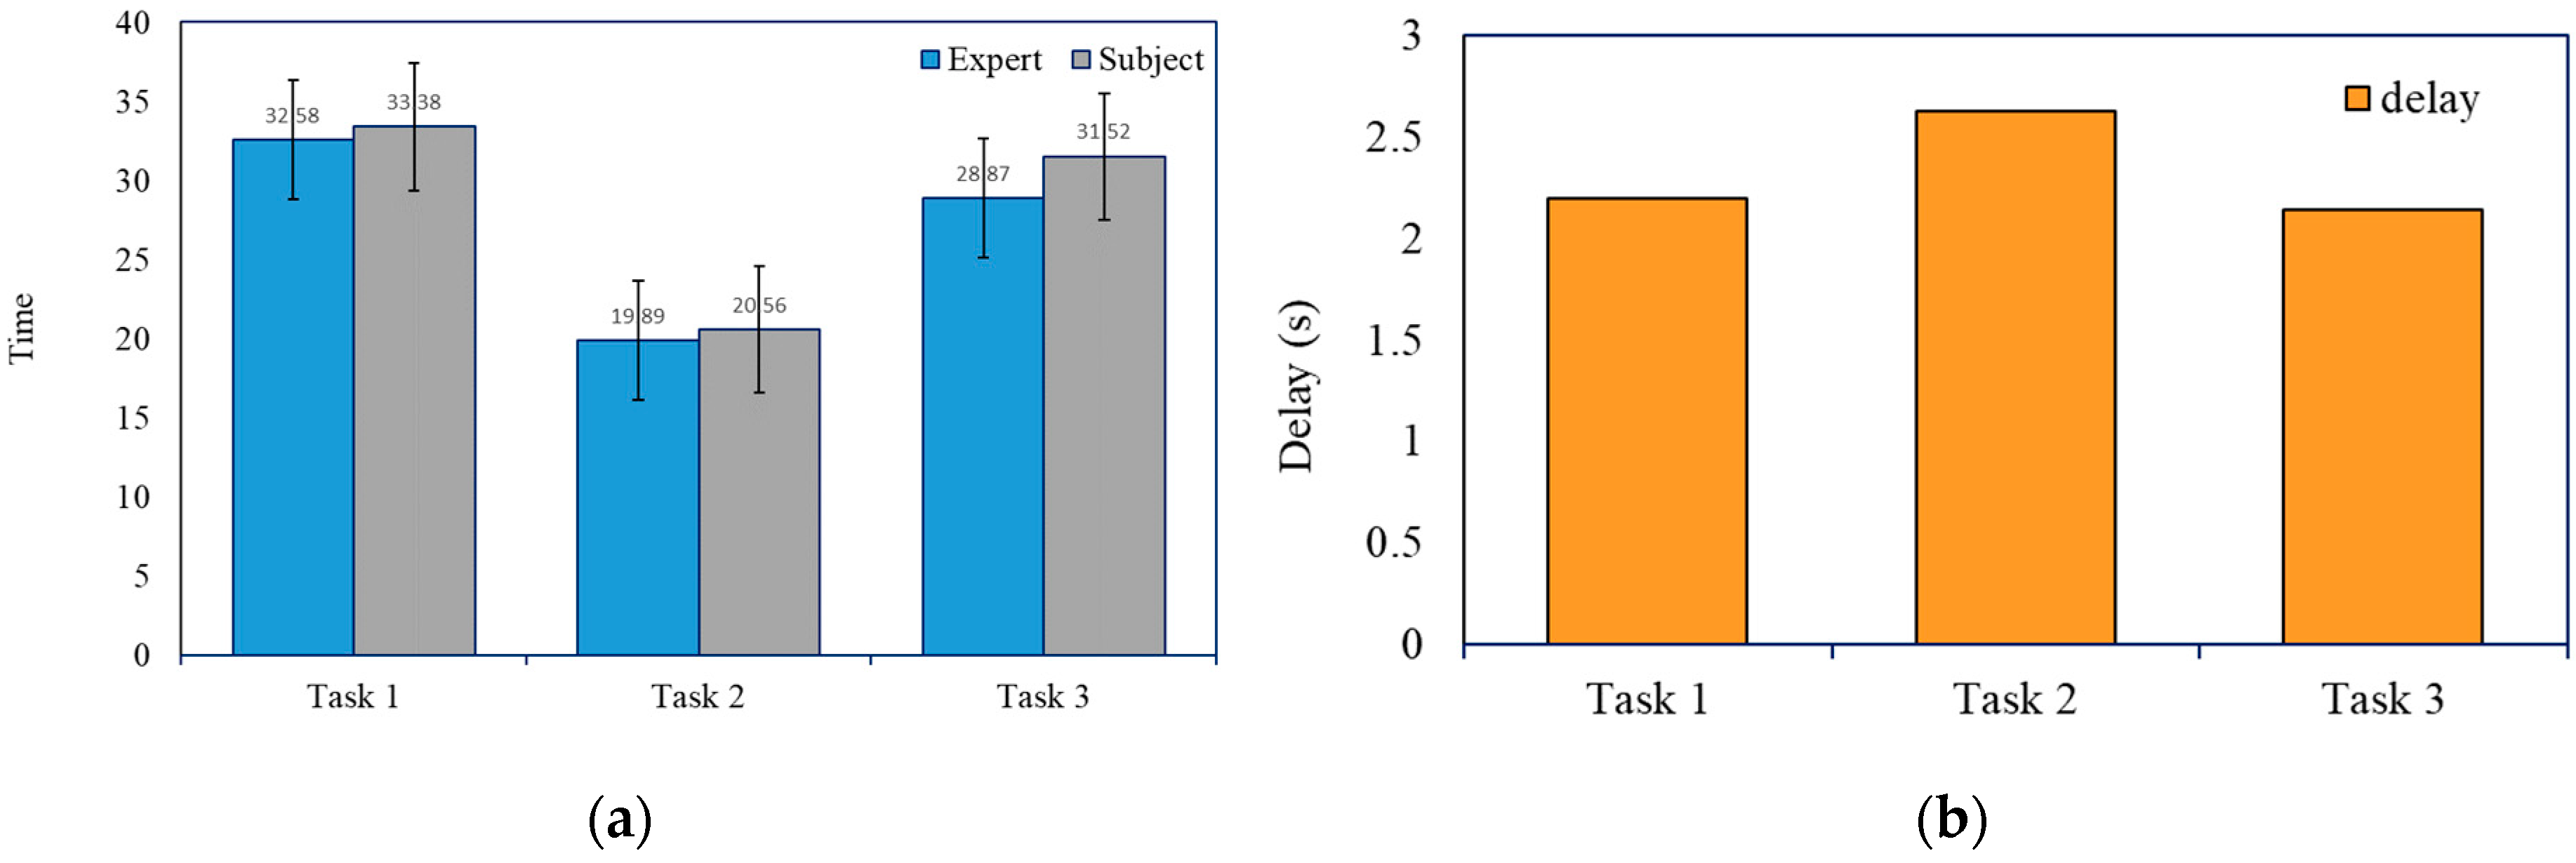
5.2. Experiment 3: Results
6. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Hai-Peng, J.; Jing-Min, X.; Wei, H.; Yi-Bing, D.; Nan-Ning, Z.H. Space station: Human exploration in space. Acta Autom. Sin. 2019, 45, 1799–1812. [Google Scholar]
- Lin, H.; Wei-Wei, F.; Hai-Ming, W. Analysis and Enlightenment of Scientific Research and Application Activities on ISS. Manned Spacefl. 2019, 6, 834–840. [Google Scholar]
- Karasinski, J.A.; Joyce, R.; Carroll, C.; Gale, J.; Hillenius, S. An augmented reality/internet of things prototype for just-in-time astronaut training. In Proceedings of the International Conference on Virtual, Augmented and Mixed Reality, Vancouver, BC, Canada, 9–14 July 2017; pp. 248–260. [Google Scholar]
- Lieberman, J.; Breazeal, C. TIKL: Development of a wearable vibrotactile feedback suit for improved human motor learning. IEEE Trans. Robot. 2017, 23, 919–926. [Google Scholar] [CrossRef] [Scilit]
- MacLean, K.E. Putting haptics into the ambience. IEEE Trans. Haptics 2009, 2, 123–135. [Google Scholar] [CrossRef]
- Feygin, D.; Keehner, M.; Tendick, R. Haptic guidance: Experimental evaluation of a haptic training method for a perceptual motor skill. In Proceedings of the 10th Symposium on Haptic Interfaces for Virtual Environment and Teleoperator Systems, HAPTICS 2002, Orlando, FL, USA, 24–25 March 2002; pp. 40–47. [Google Scholar]
- Park, W.; Korres, G.; Moonesinghe, T.; Eid, M. Investigating haptic guidance methods for teaching children handwriting skills. IEEE Trans. Haptics 2019, 12, 461–469. [Google Scholar] [CrossRef] [Scilit]
- Rosenthal, J.; Edwards, N.; Villanueva, D.; Krishna, S.; McDaniel, T.; Panchanathan, S. Design, implementation, and case study of a pragmatic vibrotactile belt. IEEE Trans. Instrum. Meas. 2010, 60, 114–125. [Google Scholar] [CrossRef] [Scilit]
- Kim, Y.; Baek, S.; Bae, B.C. Motion capture of the human body using multiple depth sensors. ETRI J. 2019, 39, 181–190. [Google Scholar] [CrossRef] [Scilit]
- Liu, S.; Zhang, J.; Zhang, Y.; Zhu, R. A wearable motion capture device able to detect dynamic motion of human limbs. Nat. Commun. 2020, 11, 1–12. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Szczęsna, A.; Skurowski, P.; Lach, E.; Pruszowski, P.; Pęszor, D.; Paszkuta, M.; Wojciechowski, K. Inertial motion capture costume design study. Sensors 2017, 17, 612. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, Z.; Zheng, R.; Kaizuka, T.; Shimono, K.; Nakano, K. The effect of a haptic guidance steering system on fatigue-related driver behavior. IEEE Trans. Hum.-Mach. Syst. 2017, 47, 741–748. [Google Scholar] [CrossRef] [Scilit]
- Devigne, L.; Aggravi, M.; Bivaud, M.; Balix, N.; Teodorescu, C.S.; Carlson, T.; Babel, M. Power wheelchair navigation assistance using wearable vibrotactile haptics. IEEE Trans. Haptics 2020, 13, 52–58. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Barontini, F.; Catalano, M.G.; Pallottino, L.; Leporini, B.; Bianchi, M. Integrating wearable haptics and obstacle avoidance for the visually impaired in indoor navigation: A user-centered approach. IEEE Trans. Haptics 2020, 14, 109–122. [Google Scholar] [CrossRef] [PubMed]
- Satpute, S.A.; Canady, J.R.; Klatzky, R.L.; Stetten, G.D. FingerSight: A Vibrotactile Wearable Ring for Assistance with Locating and Reaching Objects in Peripersonal Space. IEEE Trans. Haptics 2019, 13, 325–333. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, T.; Li, C.; Wu, C.; Zhao, C.; Sun, J.; Peng, H.; Hu, B. A gait assessment framework for depression detection using kinect sensors. IEEE Sens. J. 2020, 21, 3260–3270. [Google Scholar] [CrossRef] [Scilit]
- Protopapadakis, E.; Voulodimos, A.; Doulamis, A.; Camarinopoulos, S.; Doulamis, N.; Miaoulis, G. Dance pose identification from motion capture data: A comparison of classifiers. Technologies 2018, 6, 31. [Google Scholar] [CrossRef] [Scilit]
- Yang, L.; Yang, B.; Dong, H.; El Saddik, A. 3-D markerless tracking of human gait by geometric trilateration of multiple Kinects. IEEE Syst. J. 2016, 12, 1393–1403. [Google Scholar] [CrossRef] [Scilit]
- Napoli, A.; Glass, S.; Ward, C.; Tucker, C.; Obeid, I. Performance analysis of a generalized motion capture system using microsoft kinect 2.0. Biomed. Signal Process. Control 2017, 38, 265–280. [Google Scholar] [CrossRef] [Scilit]
- Wei-Ying, W.u.; Yu, W.; Qin, L.; Xing-Jie, Y.; Tian-Yuan, C.; Fand, P. Positioning error and its spatial distribution of motion capture with Kinect. Beijing Biomed. Eng. 2014, 4, 344–348. [Google Scholar]
- Poncet, P.; Casset, F.; Latour, A.; Domingues Dos Santos, F.; Pawlak, S.; Gwoziecki, R.; Fanget, S. Static and dynamic studies of electro-active polymer actuators and integration in a demonstrator. Actuators 2017, 6, 18. [Google Scholar] [CrossRef] [Scilit]





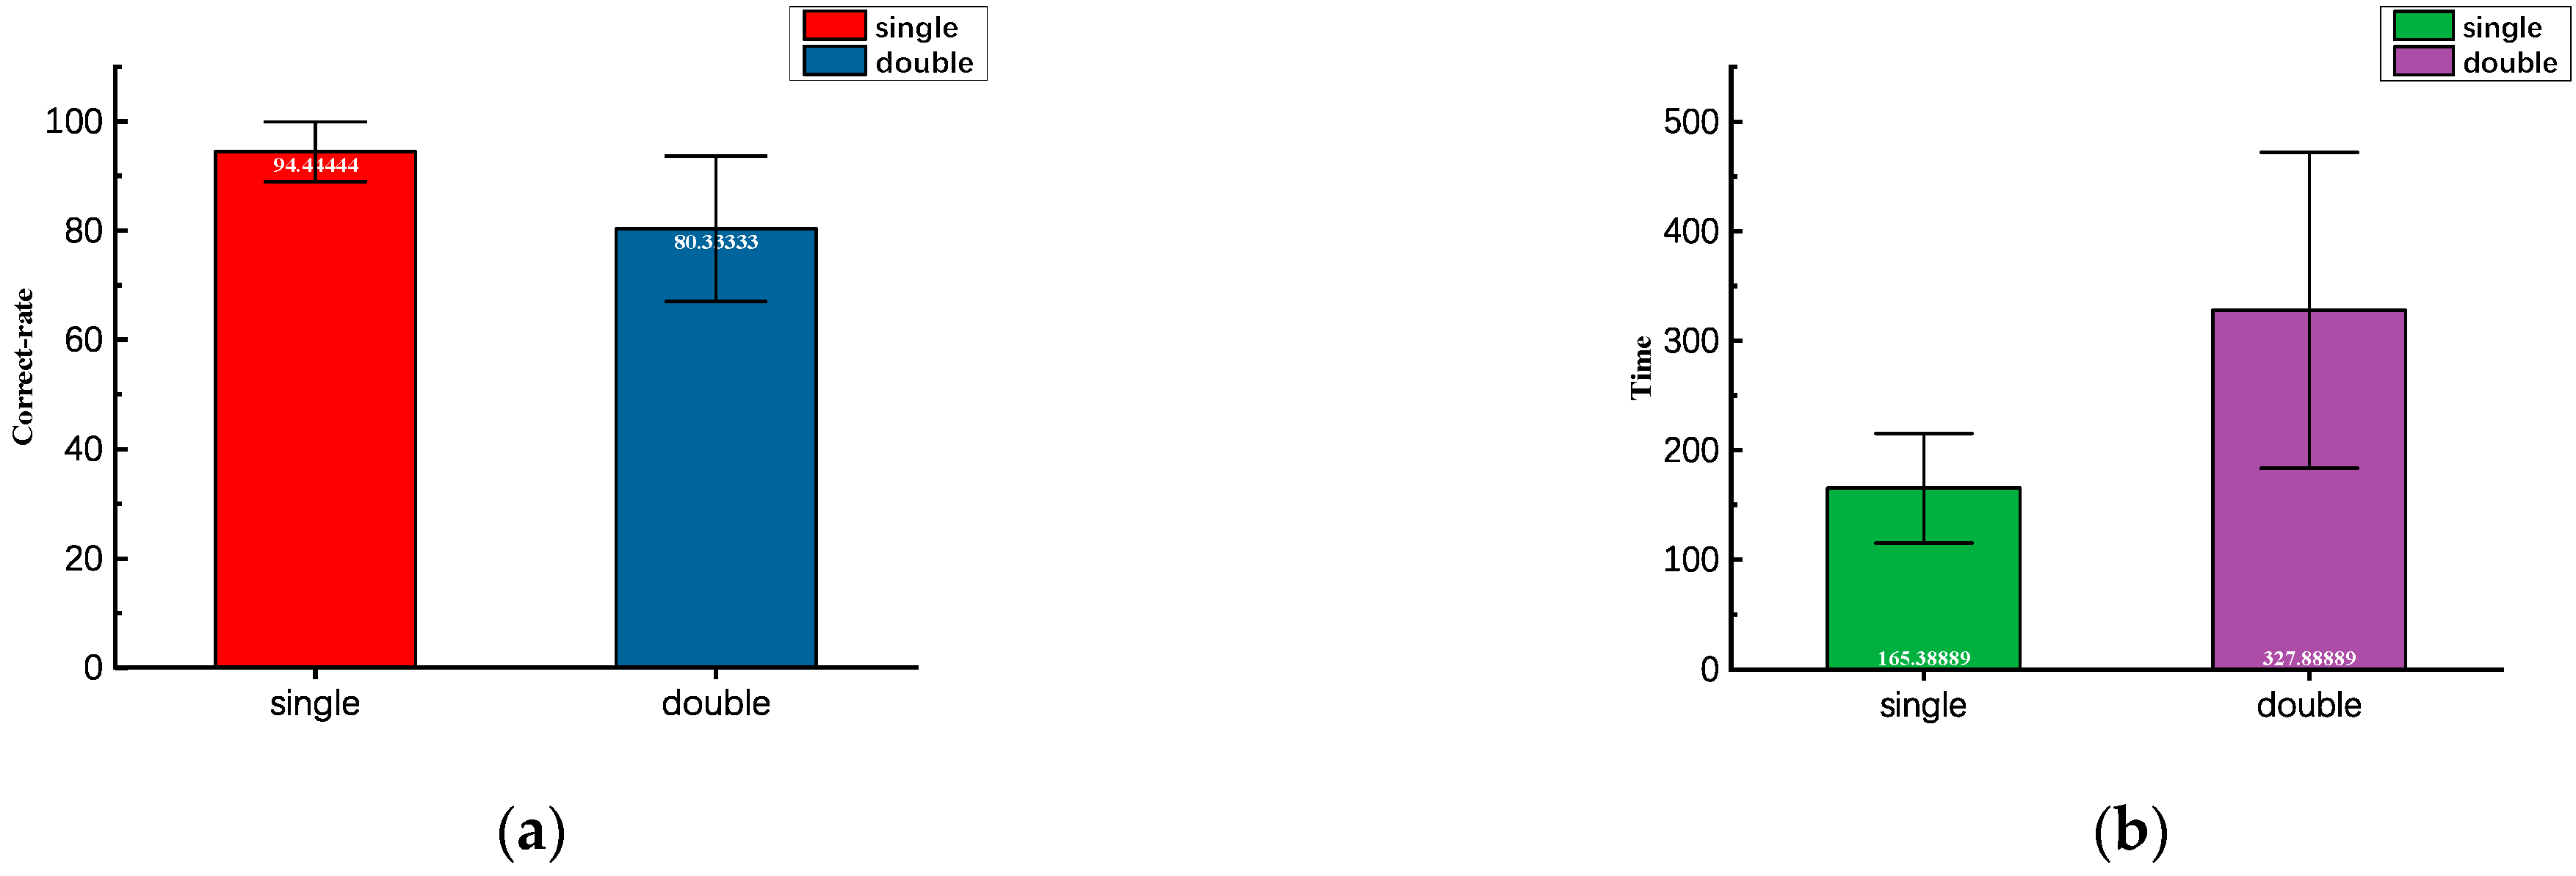


| Kinect Joint | Humanoid Joint |
|---|---|
| SpineBase | Hips |
| SpineMid | Spine |
| Neck | Neck |
| ShoulderLeft | LeftUpperArm |
| ElbowLeft | LeftLowerArm |
| WristLeft | LeftHand |
| ShoulderRight | RightUpperArm |
| ElbowRight | RightLowerArm |
| HipLeft | LeftUpperLeg |
| KneeLeft | LeftLowerLeg |
| AnkleLeft | LeftFoot |
| HipRight | RightUpperLeg |
| KneeRight | RightLowerLeg |
| AnkleRight | RightFoot |
| WristRight | RightHand |
| Guidance Information | Output Instructions | ||
|---|---|---|---|
| NONE | “−1” | ||
Additionally, points to the positive direction of x-axis | Right motor vibrates Move toward right | “002” | |
And points to the negative direction of x-axis | Left motor vibrate Move toward left | “004” | |
| and points to the positive direction of y-axis | Up motor vibrates Move toward up | “001” | |
| and points to the negative direction of y-axis | Down motor vibrates Move toward down | “003” | |
| Questions | Mean | Std. Dev |
|---|---|---|
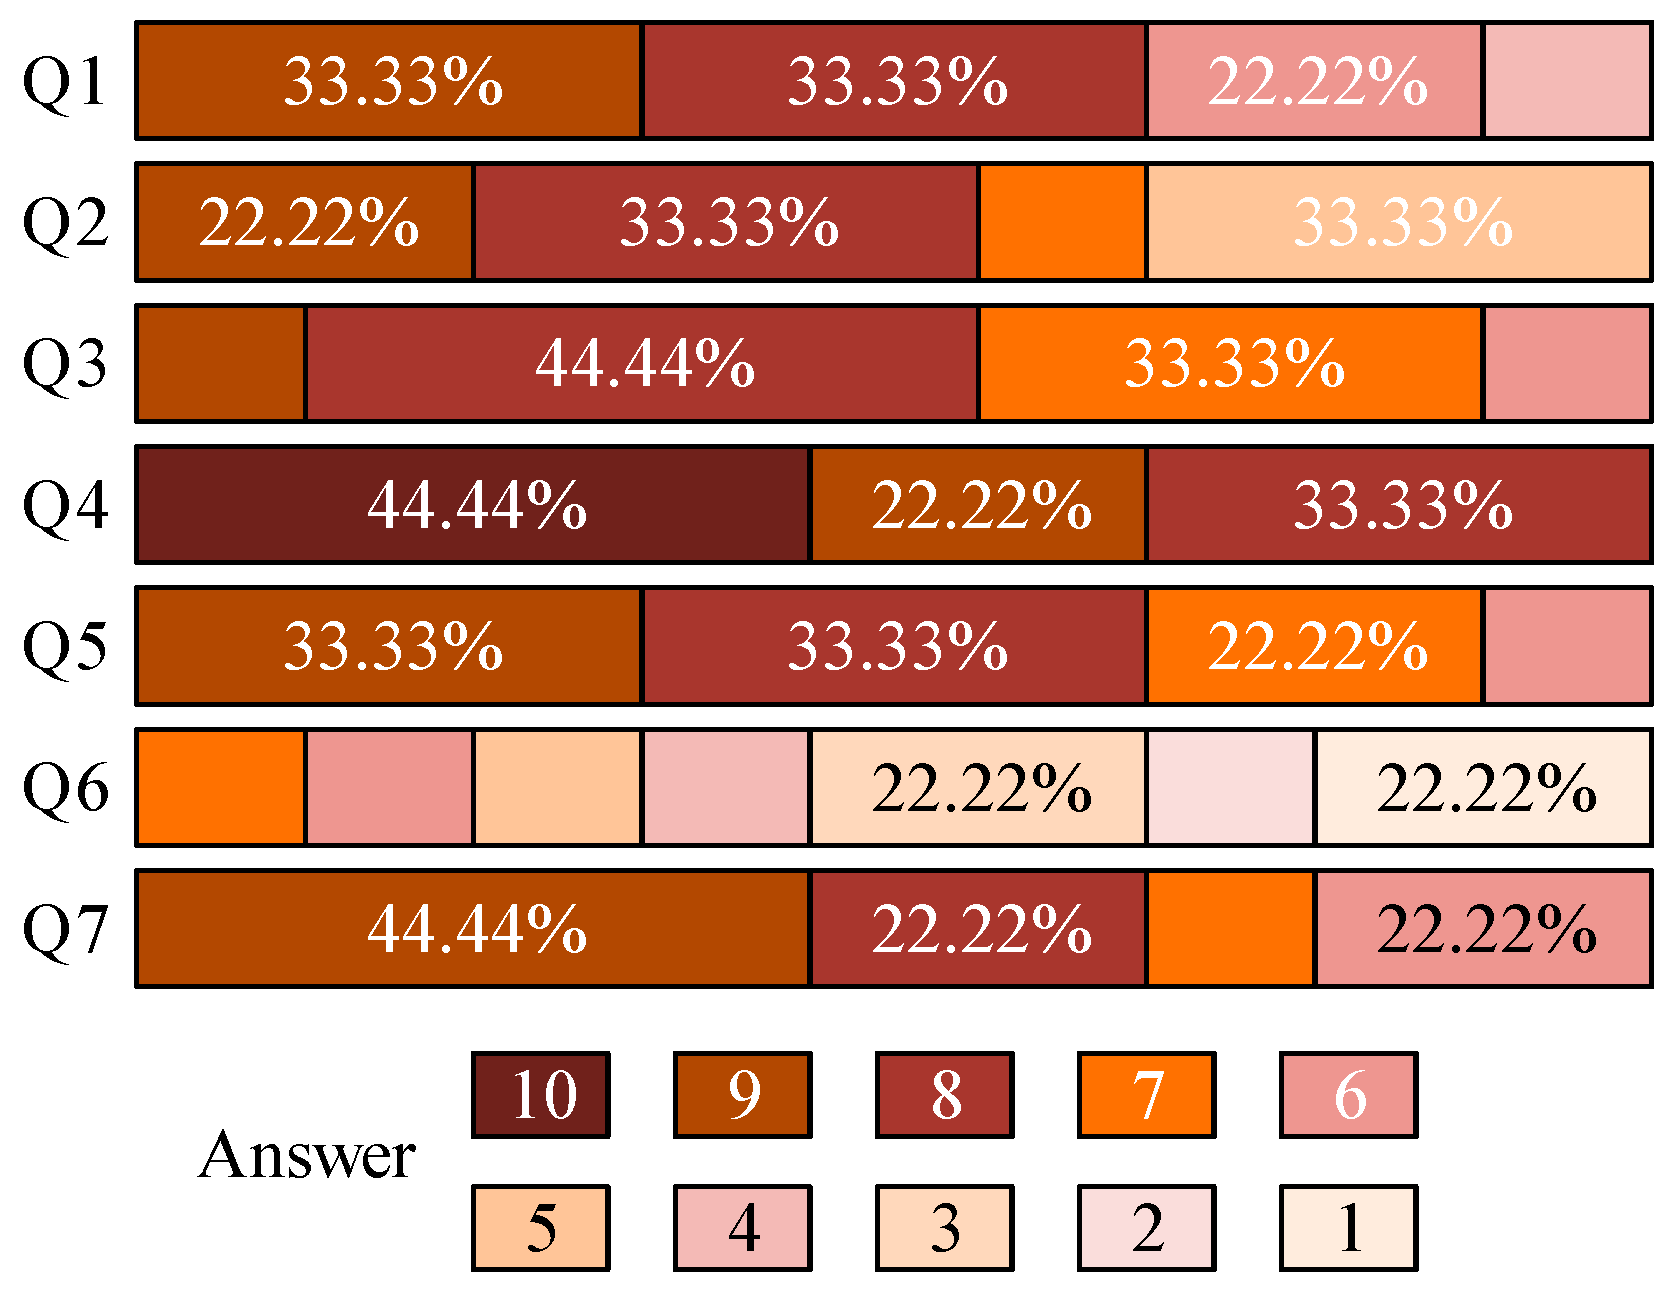
| Q1 I am familiar with the wearable haptic device. | 7.22 | 1.97 |
| Q2 It was easy to wear the haptic device. | 7.44 | 1.24 |
| Q3 I was feeling comfortable while wearing and using the device. | 7.56 | 0.88 |
| Q4 The intensity of the vibration does not make me feel uncomfortable. | 9.11 | 0.93 |
| Q5 It is very clear to recognize vibrations in different positions. | 7.89 | 1.05 |
| Q6 The noise from vibrating motors affects the recognition of the vibration position. | 3.56 | 2.13 |
| Q7 I can clearly understand the meaning of the wearable device’s guidance. | 7.89 | 1.27 |
| Accuracy of C1 | Accuracy of C2 | |||
|---|---|---|---|---|
| Subjects | First | Second | First | Second |
| 1 | 98% | 86% | 72% | 76% |
| 2 | 94% | 98% | 92% | 76% |
| 3 | 94% | 94% | 90% | 76% |
| 4 | 98% | 94% | 70% | 62% |
| 5 | 94% | 96% | 94% | 90% |
| 6 | 92% | 94% | 82% | 70% |
| 7 | 100% | 96% | 90% | 86% |
| 8 | 90% | 88% | 84% | 78% |
| 9 | 98% | 96% | 80% | 78% |
| Average | 95.33% | 93.56% | 83.78% | 76.89% |
| Number of Attempts | |||
|---|---|---|---|
| Subjects | Task 1 | Task 2 | Task 3 |
| 1 | 2 | 2 | 2 |
| 2 | 1 | 3 | 2 |
| 3 | 1 | 3 | 1 |
| 4 | 1 | 2 | 1 |
| 5 | 1 | 3 | 1 |
| 6 | 2 | 4 | 2 |
| 7 | 1 | 2 | 1 |
| 8 | 1 | 1 | 1 |
| 9 | 2 | 1 | 3 |
| Average | 1.33 | 2.33 | 1.56 |
| Mean | Std Dev | |
|---|---|---|
| Task 1 | 1.33333 | 0.50 |
| Task 2 | 2.33333 | 1.00 |
| Task 3 | 1.55556 | 0.73 |
Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2021 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).
Share and Cite
Wang, Y.; Yu, G.; Liu, G.-Y.; Huang, C.; Wang, Y.-H. Vibrotactile-Based Operational Guidance System for Space Science Experiments. Actuators 2021, 10, 229. https://doi.org/10.3390/act10090229
Wang Y, Yu G, Liu G-Y, Huang C, Wang Y-H. Vibrotactile-Based Operational Guidance System for Space Science Experiments. Actuators. 2021; 10(9):229. https://doi.org/10.3390/act10090229
Chicago/Turabian StyleWang, Yi, Ge Yu, Guan-Yang Liu, Chao Huang, and Yu-Hang Wang. 2021. "Vibrotactile-Based Operational Guidance System for Space Science Experiments" Actuators 10, no. 9: 229. https://doi.org/10.3390/act10090229
APA StyleWang, Y., Yu, G., Liu, G.-Y., Huang, C., & Wang, Y.-H. (2021). Vibrotactile-Based Operational Guidance System for Space Science Experiments. Actuators, 10(9), 229. https://doi.org/10.3390/act10090229