


Abstract
Underground gas control is a critical link in coal mine safety production, and drilling robots serve as the core equipment for gas extraction drilling operations. However, the autonomous locomotion technology of coal mine drilling robots has long been constrained by the unstructured underground environment and the limitations of existing navigation schemes, which restrict their intelligent application. To address this bottleneck, this paper conducts systematic research on key autonomous navigation technologies for coal mine drilling robots operating in narrow underground working faces, focusing on their practical operational requirements. First, a hardware scheme complying with coal mine safety standards is selected, the hardware structure and sensor layout are optimized via digital modeling, and the software interface and data interface format of the navigation system are designed. Second, an innovative 3D point cloud-based offline obstacle avoidance algorithm is proposed, which integrates a terrain analysis module, a local path planning method with maximum arrival probability, a Bézier curve-based trajectory library generation strategy, and a trajectory index construction method. Finally, simulation experiments, ground-simulated roadway field tests, and underground coal mine field experiments are performed to validate the proposed system. Experimental results demonstrate that the constructed autonomous navigation system enables smooth and safe autonomous locomotion and fixed-point parking of drilling robots, with an average parking error lower than 0.17 m, and can effectively avoid obstacles in complex environments. This research provides crucial technical support for the intelligent advancement of coal mine drilling robots.
1. Introduction
In the field of coal mine safety production, underground gas control is a key link to ensuring operational safety and improving production efficiency. Realizing the intelligent transformation of this link has become one of the core demands for the high-quality development of the current coal industry [1]. The coal mine gas outburst prevention drilling rig serves as the core equipment for underground gas extraction drilling operations. Since the 1980s, coal mining machinery companies in the United States, the United Kingdom, Australia, and other countries have developed manually operated directional drilling rigs, which have been commercially promoted and applied for gas drainage in coal seams and advanced exploratory drilling [2]. Subsequently, semi-autonomous drilling rigs emerged, capable of providing certain intelligent assistance for drilling operations. For instance, Inco Limited of Canada developed a semi-autonomous drilling rig based on the HORTA positioning system, which can ensure real-time positioning within an acceptable error range [3]. The Centre for Applied Autonomous Sensor Systems (AASS) in Sweden developed an intelligent drilling robot system (Atlas Copco), which can achieve coordinated control of multiple drilling robots, yet there remains a gap from full unmanned operation [4]. The research and development of automated drilling robots in China started relatively late. Chongqing Research Institute of CCTEG successfully developed a long-distance outburst prevention drilling rig in 2008, which enables remote wired control. In 2015, it successfully developed the ZYWL-4000SY dual-track remote-controlled automatic drilling rig, which was officially promoted and applied [5]. Later, a series of autonomous drilling rigs equipped with remote consoles for ground monitoring of underground drilling were developed [6,7]. The Xi’an Research Institute of CCTEG began to develop rapidly in 2005 and launched a series of 1000 m directional drilling rigs, such as ZDY4500LFK and ZDY6000LD, which have reached the leading level at home and abroad and can realize line-of-sight remote control via wireless remote controllers [8]. Compared with traditional operation modes, the bolter-miner-mounted drilling rig, developed by the research team of Liaoning Technical University, only requires manual operation of the hydraulic valve group to complete the start-up preparation and deployment of the drilling rig [9].
In the field of coal mine intelligent drilling equipment, domestic scholars have systematically sorted out the latest progress of geological exploration and drilling robots [10]. Currently, most relevant research on the intelligent technology of drilling robots focuses on coal-rock recognition [11], drill hole recognition [12], condition monitoring [13,14], intelligent control [7], and other aspects. For underground coal mine environmental perception technologies—such as small mobile robot positioning [15,16,17], mapping [18,19,20], and autonomous navigation technology [21]—some scholars have also conducted in-depth research. Existing reviews summarized the technical bottlenecks and development trends of inspection robots, pointing out that most existing navigation systems are designed for small equipment [22,23].
Intelligent mining has promoted the rapid development of robot navigation and path planning technologies in underground environments [24]. Improved A*, DWA, RRT*, and other algorithms are commonly used for path planning and obstacle avoidance of various mine robots in narrow tunnels [25,26,27,28,29]. Relevant studies have optimized algorithms against underground environmental interferences, such as obstacles and poor visibility [30,31]. However, no research team has carried out relevant research on the reliable autonomous navigation capabilities of drilling robots, which is considered key support for determining the intelligence and unmanned level of gas control.
The intelligence of drilling robots can not only reduce safety risks caused by manual intervention but also significantly improve the accuracy and operational efficiency of drilling construction. However, constrained by multiple factors in the underground unstructured environment—including dim light, complex terrain, and narrow spaces—coupled with the limitations of existing navigation schemes in terrain adaptability and stability, the autonomous walking technology of coal mine drilling robots has long faced a bottleneck. It is difficult to meet the operational requirements in special scenarios such as narrow working faces, which has become a major obstacle restricting the intelligent application of such robots. To clearly present the research status and technical gaps in this field, we compare representative existing studies and the proposed work in Table 1.
Table 1.
Comparison with state-of-the-art related works.
As shown in Table 1, most existing drilling rigs rely on manual or remote control, while current navigation technologies are mainly designed for small mobile robots and cannot adapt to large-scale heavy-duty drilling robots with large aspect ratios. To address this industry pain point, this paper focuses on the actual operational needs of coal mine drilling robots in underground narrow working faces and conducts systematic research on key autonomous navigation technologies. By analyzing the motion laws of drilling robots, an autonomous navigation system adapted to underground scenarios is constructed, covering architecture design, scheme selection, and software and hardware development. Meanwhile, to solve the obstacle avoidance problem in unstructured environments, an offline obstacle avoidance algorithm based on 3D point clouds is innovatively designed to break through the limitations of existing technologies and achieve smooth, safe autonomous walking of robots in complex terrain. This research provides technical support for the intelligent development of coal mine drilling robots.
Most existing local and global planners, such as A*, DWA, and sampling-based planners, rely on 2D occupancy grid maps. Such 2D mapping solutions are vulnerable to map degradation in underground coal mine roadways with monotonous scenes, repeated structures, and uneven terrain, resulting in poor positioning and navigation stability. Different from the above methods, the navigation system proposed in this paper takes a 3D point cloud as the core data source. The 3D perception architecture can acquire rich terrain and spatial information and effectively suppress map degradation in similar underground environments. As shown in Figure 1, we compared the traditional hybrid A* algorithm based on 2D maps with the navigation method based on 3D maps proposed in this paper in narrow road scenarios. It can be seen that the 3D map delivers better anti-degradation performance under the same environment.
Figure 1.
Comparison results of navigation experiments: (a) navigation failure case of the hybrid A* algorithm based on a 2D environmental map. The thick solid green line in the figure denotes the planned motion trajectory, the yellow shape represents the robot model, lines formed by black point clouds correspond to the prior tunnel map, the gray area is the inflated region of the prior map, lines composed of purple point clouds indicate the robot’s current sensing area, and the cyan region stands for the real-time inflated area. (b) Navigation result of the proposed method based on a 3D environmental map. The white shape is the robot model. Short red (x), green (y), and blue (z) pillars denote the base coordinate axes of the robot. Yellow lines in front of the robot are traversable paths, and spaced colored dots behind the robot mark the traveled trajectory. The purple sphere represents the navigation target point of the robot. In the environment, the colored point clouds transition from red to purple, corresponding to point cloud heights from low to high.
The concept of path planning and feasible trajectory generation directly based on point cloud data has been proposed in related research on UAVs [32] and ground robots [33]. This concept is improved and expanded in this paper to be directly applicable in underground coal mine environments. Figure 2 shows the application demonstration scenarios of the navigation system studied in this paper on two types of drilling rigs. The contributions of this research are summarized as follows:
Figure 2.
Two models of drilling robots and their autonomous navigation interfaces: (a) Model A is from the Chongqing Research Institute of CCTEG; (b) Model B is from the Xi’an Research Institute of CCTEG. In the figure, the robot model is rendered in gray, yellow lines in front of the robot are traversable paths, red lines denote traveled trajectories, purple sphere represents navigation target point. In the environment, the colored point clouds transition from red to purple, corresponding to point cloud heights from low to high.
- Aiming at the characteristics of the underground coal mine environment and the application needs of drilling robots, a hardware scheme that meets coal mine safety standards is selected. The hardware structure design and sensor layout of the mobile test platform are optimized through digital modeling, the navigation system software interface is developed, and the data interface calling format of the drilling robot is designed.
- A trajectory generation method based on an offline lookup table is proposed, which can generate safe and dynamically feasible trajectories in the terrain analysis map. This method utilizes the characteristics of Bernstein polynomial basis functions to convert trajectory generation from cubic polynomial curves to Bézier curves, which can provide a smoother trajectory during underground movement.
- A complete autonomous navigation system applicable to large-scale underground coal mine drilling robots is constructed for the first time, integrating the proposed path planning framework with state estimation, perception, and control modules. Through benchmark comparison tests, ground experiments, and field tests, this paper verifies the feasibility and robustness of the constructed navigation system.
3. Autonomous Obstacle Avoidance Method for Underground Unstructured Terrain
The core architecture of the autonomous obstacle avoidance method for underground unstructured terrain is shown in Figure 12. The complete perception system includes three types of sensors: lidar, IMU, and a UWB positioning base station, which can be flexibly selected according to actual application scenarios and requirements. The autonomous obstacle avoidance method is mainly implemented by constructing an environmental point cloud map based on the point cloud information provided by the 3D lidar. Firstly, terrain analysis is performed on the laser point cloud to segment the feasible region. Secondly, maximum likelihood probability path searching is conducted within the voxel-gridded feasible region to obtain a global probability density transmission map. Afterwards, collision detection is carried out in the pre-generated trajectory library to acquire a feasible trajectory tree. Subsequently, the optimal trajectory is selected according to environmental constraints and guidance rule constraints. Then, it is determined whether to adopt the MPC trajectory tracking method for optimal trajectory tracking control based on specific control requirements. Finally, control commands are transmitted to the driving nodes of the robot chassis, and a PID controller is used to regulate hydraulic valves to drive the rotational speeds of the two left and right hydraulic motors of the robot, thereby realizing the walking motion of the drilling robot.
Figure 12.
Software architecture of the autonomous navigation system for unstructured terrain.
3.1. Terrain Analysis Module
The execution effect of autonomous obstacle avoidance is closely related to the quality of the point cloud map. Therefore, the quality and quantity of point cloud information acquisition are particularly important. This study realizes the acquisition of point cloud information based on our previous work [15,18]. Figure 13 shows the test results of environmental map construction using the LIU-SLAM algorithm in a building with a similar roadway structure. It can be seen from the figure that the generated 3D laser point cloud map has a good effect, with obvious concave–convex details of the walls and a clear steel frame structure on the top of the building hall, without serious degradation problems. This indicates that the LIU-SLAM algorithm can obtain accurate point cloud information, laying a foundation for subsequent terrain analysis in the point cloud environment.
Figure 13.
Point cloud map generated by LIU-SLAM.
Figure 14 shows the flow chart of terrain analysis and processing. This module checks the local terrain around the robot by reading the height of the laser point cloud. In this paper, two types of terrain elevation information maps in the environment around the robot are constructed as obstacle avoidance maps. The two elevation information maps have different regional scopes and resolution sizes. The first is a local planar voxel elevation map with a resolution of 0.1 m within a 10 m × 10 m area. This map takes the lowest point in each group of voxels as the voxel height value within this range, defines it as a passable interval, and takes the height of other points relative to the lowest point as the passing cost, which is mainly used for path planning within a local range. The second is a global terrain point cloud elevation map with a resolution of 0.2 m within a 40 m × 40 m area, which is mainly used to distinguish passable and impassable areas in the upper-layer planning algorithm and segment the feasible ground area based on this map to realize terrain analysis of the regional environment. In addition, the terrain analysis module can handle blank data point areas caused by negative height or no data on the topographic map. When this function is turned on, these two types of areas will be defined as impassable states. Since this module maps the height information of point cloud information within a certain area instead of directly processing the point cloud, it has an extremely fast processing speed.
Figure 14.
Flow chart of terrain analysis and processing.
Figure 15 shows the terrain segmentation processing diagram in a sloped area. It can be seen from the side view that the robot experiences a walking process of a large, gentle slope—flat ground—short bulge—flat ground. The voxels in the figure are displayed based on the spectral interval, and the color change from red to green represents the gradual decrease in the passing cost. It can be seen from the isometric view that the impassable areas are represented in red, indicating extremely high passing costs; while most of the feasible areas are green, there are differences. The green of the slope area is relatively lighter, and the voxels at the short bulge are yellow. This indicates that although they are all passable areas, the passing cost of the slope area is higher than that of the flat area.
Figure 15.
Visualization of terrain segmentation processing. The coordinate axes in the figure represent the base coordinate system of the robot.
3.2. Local Path Planning Method Based on Maximizing Arrival Probability
The path planning problem within a certain area can be defined as a probabilistic model [33]. As shown in Figure 16, the blank area in the figure is defined as the robot’s configuration space. The light blue area represents the scanning range of lidar or other sensors. The purple solid circle denotes the detection boundary of the omnidirectional sensor, while the dashed line indicates the field of view of the directional sensor. The orange cylinder is the obstacle area. and are the robot’s current position and target position, respectively. Based on the basic principles of probability, the obstacle information within the range has two states: deterministically known (obstacles fully presented) or probabilistically known (obstacles partially presented).
Figure 16.
Schematic diagram of path planning based on a probabilistic model.
Let the robot’s current state be . When the robot is in a non-fully enclosed environment, there are multiple directions and paths from the current position A to the target point B that satisfy the robot’s kinematic constraints, depending on different conditions. Define the probability of successfully reaching the target point B from a given state as . Then, the path planning problem within the limited sensor range can be defined as the robot finding a state that maximizes the probability of reaching the target point B from all current states at each moment during navigation:
With the target point fixed, solving Equation (1) ensures that the robot maintains the state of maximum arrival probability throughout the process of moving towards the target point. The path of the robot from the known environment to the target point in the unknown environment is continuous. Therefore, all feasible paths must pass through the sensor detection boundary , and there exists a state that divides the robot’s navigation behavior into two segments: the red line in the figure represents the navigation path within the range , and the green line represents the path in the area outside the sensing range. When using an omnidirectional sensor, all possible paths of the robot intersect with , but this does not mean all paths are feasible, as they must comply with the robot’s kinematic constraints, which limit the number of current states . When using a directional sensor, since its direction is always the same as the robot’s movement direction, the condition that feasible paths must intersect with R is also satisfied. In the above definition, the obstacle probability within the range is known, so the conditional probability distribution of the red path can be calculated. The prior map can provide the obstacle probability for the area outside the detection boundary to calculate the conditional probability distribution of the green path. In the absence of a prior map, only the obstacle probability distribution within the current sensor detection boundary is used as the benchmark. Define the probability density function of the robot’s current state as , then the overall probability density of the path is obtained by integrating the probability densities inside and outside the detection boundary :
Since the number of samples in must be a positive integer, i.e., , a stochastic approximate inference can be performed using the Markov Chain Monte Carlo (MCMC) method to obtain the following form:
Treating n as a constant, the above equation can be expressed as the discretized form shown in Equation (4):
That is, the continuous probability distribution problem of can be approximately solved using a finite number of () important samples. In this way, the computer can solve the navigation problem using a finite number of discretized paths and voxels.
3.2.1. Global Probability Density Distribution
Unlike the voxel grid with only position information obtained by SLAM modeling, the probability density voxel grid contains both position and direction information. Within the voxel plane of the feasible interval, the probability transfer relationship can be defined as shown in Figure 17.
Figure 17.
Schematic diagram of voxel probability transfer: (a) schematic diagram of voxel representation method; (b) probability relation transmission graph.
Define the robot state within a voxel as , where is the voxel index and is the direction index. As can be seen from Figure 17a, each voxel contains constant angular intervals in multiple directions. A voxel numbered can be uniformly divided into directions at a certain angle, where is the number of movement directions of the robot within the voxel. As shown in Figure 17a, it indicates that the robot in the current state has movable directions when . Figure 17b shows the probability transfer relationship of voxels. The state where the robot moves forward at a certain angle in the current voxel can receive probability information transferred from the adjacent voxels on its left and right sides ( and ).
Figure 18 is a schematic diagram of the proportion of voxel direction probability transfer. It can be seen from the figure that the direction of transferred probability divides each adjacent voxel into two parts. The green area is intercepted by a straight line parallel to the state passing through the voxels and , with one end of the straight line intersecting the left and right vertices of the voxel . The area within this interval can be regarded as the probability magnitude passing through the voxel. In a voxel with a unit size of 1, when the angle between the target direction and the given coordinate system is , the probability passing through is , and the probability passing through is . Similarly, when the target direction is parallel or perpendicular to the coordinate axes, the probability propagation between voxels will not pass through the other voxel.
Figure 18.
Schematic diagram of the proportion of voxel direction probability transfer. The red arrows in the figure indicate the direction of probability propagation.
Due to the tight connection between voxels in the elevation map, each voxel has three directions to transmit probability information to the target voxel. Therefore, the probability transfer relationship between adjacent voxels can be calculated, and thus the probability density of reaching the target point B from the state can be obtained:
In the formula, represents the passability of the voxel, indicates that the voxel is a passable interval, and indicates that the voxel is completely occupied by obstacles and is impassable. and , respectively, represent the probability distributions of the robot moving forward and rotating at a yaw angle. As mentioned above, there are three directions for probability propagation from a voxel to other adjacent voxels, including one forward probability and two rotation probabilities , with the following relationship:
This formula indicates that the overall probability of the robot moving from the current voxel to the next voxel is 1. In the absence of a prior map, the following heuristic function can be used for calculation:
In the formula, represents the relative difference between the current and the target direction yaw angle. That is, the path direction selected by the robot is preferentially biased towards the target direction.
3.2.2. Local Probability Density Occupancy Model
After discretizing the continuous probability model through Monte Carlo sampling, a limited number of discretized paths can be used to solve the navigation problem. The density and quantity of paths will affect the accuracy and success rate of navigation. Given the initial state , the arrival probability at the state points on the sensor detection boundary from the starting point within the sensor range (local map) can be approximated by sampling the detection boundary . In the selection of module schemes for the autonomous navigation system, it is proposed that the autonomous obstacle avoidance module adopt an offline obstacle avoidance scheme. Therefore, this section generates a discrete trajectory library based on the initial state . The trajectory library stores a path set with multiple path groups as retrieval sequences, and each path has its own group and an independent number. The specific path to be executed is determined by continuously querying the number values in the path set during navigation.
During navigation, the sensor continuously provides environmental data information for the obstacle avoidance algorithm, which is displayed as an elevation map and a feasible interval. Voxel points that reach the height threshold are considered obstacle points. The probability occupancy model defined in this section uses the elevation map to determine whether a voxel blocks a certain path in the path set. Figure 19 shows a schematic diagram, where the middle path bundle in the path set is occupied by a deterministic probability obstacle (light blue circle) within the sensor scanning range . The sub-path occupied by the obstacle no longer appears in the current path bundle, and the robot will select one from the other paths for tracking and movement to achieve the autonomous obstacle avoidance function. It can be seen that the starting point of the path bundle is , and the path endpoint (terminal sampling point) is the discrete sample obtained by Monte Carlo sampling within the conditional probability distribution . Since the generated path bundle only exhibits divergent paths in different directions at the middle segment, this obstacle avoidance method has a certain predictive ability for the state of the surrounding environment.
Figure 19.
Schematic diagram of the path bundle based on probability occupancy.
The paths in the path set are all feasible paths from to the sensor detection boundary . Each path has an independent number corresponding to the sampling point of the terminal state . To eliminate paths that collide with obstacles during navigation, a Boolean function is defined to describe the two states of the path: occupied by obstacles and not occupied by obstacles. The specific form of is as follows:
According to the Importance Sampling (IS) theorem in the Monte Carlo integration sampling theorem, by assigning different weights to each sample , the expected value can be calculated using the weighted average method. Therefore, Equation (8) can be substituted into Equation (4) as a weight parameter to obtain the following local probability occupancy model:
This model defines that when the probability of a path from the initial state to the terminal state becomes 0, the path will not be considered when selecting feasible paths. Moreover, when Equation (9) is applied to the entire path set, the path where the state with the maximum arrival probability in the path set is located will be selected as the robot’s execution path.
3.3. Trajectory Library Generation Based on Bézier Curve
A Bézier curve is a commonly used spline curve in engineering design, which has the characteristics of continuous differentiability, convex hull property, geometric invariance, etc., and always passes through the starting and ending points. Therefore, it is very suitable for the optimization of robot motion control quantities (velocity, acceleration, jerk, and snap). A section of the Bézier curve is usually composed of Bernstein polynomial bases, where the i-th order Bernstein polynomial basis is defined as:
The expression of a traditional Bézier curve composed of n-th order Bernstein bases is as follows:
In the formula, represents the control point set of the j-th segment of the Bézier curve, and C is the symbol of combination in permutation and combination.
Since the Bézier curve does not pass through the intermediate control points, to generate a more suitable Bézier curve, an idea similar to the quasi-uniform B-spline is adopted. A small variation τ is defined, so that constraint points are added around the intermediate control points, except the start and end points of the Bézier curve, and the number of constraint points is controlled by the constraint point vector . The specific constraint point conditions are as follows:
In the formula, key represents the serial number of the intermediate control point.
Figure 20 shows the offline trajectory generation diagrams of a cubic spline curve, a Bézier curve without constraint points, and a Bézier curve with two constraint points, with a variation of 0.001 added around each control point. Figure 20a is the generation benchmark of the offline path lookup table using a cubic spline curve adopted in the literature. It can be seen from the figure that the path is distributed into three segments, starting from the initial point with seven path group branches, each path group branch has seven sub-branches, and each sub-branch has seven endpoints, totaling 343 paths, and the starting point of each segment must pass through the control points. Figure 20b is the trajectory diagram generated by a general Bézier curve. With the control points unchanged, due to the characteristics of the Bézier curve, all paths are scattered within the convex hull formed by the control points and have almost no bends, which is obviously very unfavorable for obstacle avoidance. Figure 20c is the path set generated according to the generation rules of Equation (12), where and are defined; that is, two constraint points are added on both sides of each intermediate control point. It can be seen from Figure 20c that the generated paths can be closer to the control points, the paths have obvious twists, and the sampling distribution is more uniform in a limited area than that in Figure 20a, which is conducive to more accurate path selection and obstacle avoidance within the sensor detection area. Figure 20d is a comparison diagram of the sub-path bundles extracted from the three path sets. It can be seen that, regardless of the shape of the path, the sampling positions of the initial state and the boundary state are unchanged, and the sub-path bundles generated based on the constraint points have a more uniform distribution compared with the cubic spline curve sub-path bundles.
Figure 20.
Comparison between different path set forms and sub-path bundles: (a) cubic spline curve (C-SC); (b) original Bézier curve (O-BC); (c) Bézier curve with constraint points (C-BC); (d) comparison of the curve shapes of the three path generation methods.
The advantage of the offline obstacle avoidance algorithm lies in the pre-generated offline trajectory library, which omits the step of online calculation of obstacle avoidance paths and can ensure a low computational load during the robot’s autonomous obstacle avoidance. Therefore, we adopt the autonomous navigation method of “offline trajectory library generation + online trajectory lookup table” to ensure rapid response during the operation of the drilling robot. However, the offline obstacle avoidance algorithm needs to consider two issues: the generation time and the file size of the offline trajectory library. Depending on the calculation parameters, the time and file size used for trajectory generation are also inconsistent. Larger files will lead to a longer lookup time during online use, and a longer trajectory library generation time affects the portability of the algorithm, meaning that trajectory generation needs to be performed on a more powerful computer. Figure 21 compares the time used for generating offline trajectory libraries, the size of trajectory lookup table files, and collision detection files between cubic spline curves and Bézier curves under the same generation parameters. It can be seen from the figure that the trajectory library generated based on Bézier curves has certain advantages in terms of total calculation time and file size.
Figure 21.
Comparison of trajectory library generation time and file size between cubic spline curves and Bézier curves. Traj. Gen.: Trajectory Generation; Traj. Stor.: Trajectory Storage; Collis. Calc.: Collision Calculation; Collis. Stor.: Collision Storage.
3.4. Trajectory Index Establishment Method
Figure 21 shows a schematic diagram of sensor perception area modeling. The figure displays the state when generating the detection index file in MATLAB 2021b and the range of collision detection in the simulation environment, where the black dots represent the obstacle information set at the center of the voxels, and their coverage shape is equivalent to the detection range of the directional sensor. The sensor detection range is set to 6.4 m × 9 m, which exactly covers the range of the accurate elevation information map. To facilitate the display of the path set in the image, the voxel density in Figure 22a is defined as 0.2 m × 0.2 m, so this range contains a total of 33 × 91 voxel obstacle information and covers all paths. The elevation information map corresponds to the voxel grid in this figure, and each row in the index file corresponds to a certain voxel grid, shown in Figure 22b, which is used to detect the indexes of all paths passing through this obstacle, define the probability occupancy state attribute for these paths based on Formula (8), and realize the selection of collision-free paths by real-time checking this file in online planning. Since the path has no width attribute, it is also necessary to consider the robot’s collision radius when calculating collisions. For the drilling robot, after actual on-site tests, setting the collision radius to half of its vehicle width achieves the best effect. When the autonomous obstacle avoidance algorithm is started, the terrain analysis module continuously receives the point cloud information sent by the sensor and converts it into a local elevation information map and a feasible interval, then calls the collision detection index file to find the path indexes blocked by obstacles to eliminate collision paths, and the remaining paths are free paths. To further select a suitable obstacle avoidance path from the free paths, the selection rules of the optimal path will be elaborated next.
Figure 22.
Schematic diagram of sensor perception area modeling: (a) path-voxel collision mapping table; (b) schematic diagram of collision detection range. The axes Red (x), Green (y), Blue (z) in the right figure correspond to the robot base coordinate system. The yellow lines denote traversable paths for the robot, the red lines represent laser point clouds scanned on the ground, and the multicolored point clouds stand for obstacles in the environment, where the color gradient from red to purple indicates an increase in point cloud elevation.
3.4.1. Maximum Arrival Constraint
Formula (1) converts the path planning problem into a problem of calculating the maximum arrival probability. Therefore, the first selection rule for the optimal path is to find a path that maximizes the probability of reaching the target point for priority execution. The autonomous obstacle avoidance algorithm needs to traverse all paths in the path set and calculate according to Formula (9); that is, select the corresponding path bundle according to the following formula:
3.4.2. Unidirectional Travel Viewpoint Constraint
In the roadway environment, although the coal mine drilling robot can walk forward and backward along the roadway direction, as shown in Figure 23, the rear part of the drilling robot has a large drill bit, and the laser point cloud cannot pass through this area. Therefore, to prevent the robot from selecting a path backward according to the established prior map when there is no point cloud at the rear, a constraint rule for a unidirectional travel viewpoint is defined. When there is no point cloud information, ; that is, the arrival probability in the area without a point cloud is 0:
Figure 23.
The perception area of sensors on the drilling robot: (a) working status of the drilling robot; (b) real-time point cloud information display diagram of the navigation interface. In the figure, the robot model is rendered in gray, red lines denote traveled trajectories. In the environment, the colored point clouds transition from red to purple, corresponding to point cloud heights from low to high.
To prevent the drilling robot from reversing or turning in place inside the roadway, besides setting the traversal probability using Equation (14), we designed a dedicated function to control in situ rotation at the software level, and disabled turning during field experiments.
3.4.3. Orientation Constraint and Voronoi Diagram Constraint
The path selected by the local path planning model based on maximizing arrival probability is usually determined based on the minimum cost, so it tends to walk close to the wall when turning. However, this path selection method is not suitable for robots with a large aspect ratio, such as coal mine drilling robots, which are prone to scratches when turning due to excessive pursuit of minimum cost. Therefore, to deviate the path slightly away from the wall, this section proposes a combination function to screen the optimal path that is relatively far from the wall. The combination function includes a target orientation function and a Voronoi diagram-based constraint function :
where the target orientation function is as follows:
In the formula, is the angle difference between the path and the target point, is the angle difference between the path direction and the current vehicle orientation, is the weight of the target orientation function, and is the path direction weight.
in Formula (17) adopts a similar processing method to that in reference [34], guiding the path away from obstacles through nodes in the Voronoi field:
In the formula, represents the weight of the Voronoi diagram constraint term, is the distance to the nearest obstacle, and is the nearest edge of the Generalized Voronoi Diagram (GVD). represents the maximum distance of the Voronoi diagram edge. is a parameter controlling the GVD attenuation rate, is a constant of the maximum effective range of obstacle distances in the environment, and when , . It should be noted that in practical applications, the resolution of the Voronoi diagram grid is consistent with the voxel grid map generated by terrain analysis, which can greatly reduce the computational load of the system.
3.5. Model Predictive Control Controller
The kinematic system of the tracked differential model is typically a non-complete constrained system at low-speed conditions. According to the literature [35], the kinematic model of the robot is defined by a generalized coordinate system that comprises the coordinates (x, y) of the center of rotation of the track and a heading angle θ with respect to a fixed Cartesian coordinate system:
where the control inputs v(t) and w(t) are the linear and angular velocities of the robot, respectively. Let be the desired position attitude of the robot, be the desired coordinates, and be the desired heading angle, and the desired trajectory can then be expressed as:
By combining (18) and (19), the control quantity of the robot’s trajectory tracking problem and the output quantity can be determined as and , respectively. The linear MPC trajectory tracking problems can be solved by QP. A trajectory tracking controller for the drilling robot was designed, as shown in Figure 24.
Figure 24.
Block diagram of the trajectory tracking controller for the drilling robot. σr and Θr denote the desired input and output of the robot, respectively. ∆σ denotes the optimal control volume solution set, and ∆Θ denotes the error between the current actual position and the desired position. σ and Θ denote the actual input and output, respectively.
The trajectory tracking control task consists of finding the appropriate control quantity to make the error between the current actual position and the desired position of the robot as small as possible. The quadratic function of the deviation of the state quantity and the deviation of the control quantity of the robot is used as the objective function. The general form of the optimization function is given by:
where N represents the control prediction duration, Q represents the weight matrix of robot states, and R represents the weight matrix of robot control quantities.
The optimization problem is redesigned in the form of quadratic programming, which leads to the following form:
where H is a Hessian matrix with positive values describing the quadratic part of the objective function, vector f describes the primary part of the function, and A and B are rolling optimization matrices related to the defined optimization time. The trajectory tracking optimization function of the MPC controller, under the non-complete constraint of the differential motion model, is obtained. The QP method can be used to find the optimal solution of the objective function at each sampling moment t. The control system can obtain a series of optimal control sequences at the same moment, and the controller will select the first parameter (i.e., the optimal control parameter) in the control sequence at the current time point, which is the final result.
Since the control inputs to any system have physical limits, the inputs to the controller should be constrained accordingly to prevent the system model mismatch. When MPC performs an optimal solution, upper and lower limits on the control inputs should be set:
4. Experimental Methods and Analysis
4.1. Simulation Experiments
- (1)
- Comparison with baseline methods
The simulation experiments were carried out in the Gazebo simulation software, using the Tunnel simulation test environment built by CMU [36]. In the Tunnel simulation environment, autonomous navigation experiments with unidirectional travel viewpoint constraints were mainly conducted to test the effectiveness of the unidirectional viewpoint constraints. Two types of trajectory library files, generated based on cubic spline curves and Bézier curves, were compared. Due to the large test area, the robot’s moving speed was set to 2.0 m/s, and the angular speed was 0.5 rad/s. The robot traveled unidirectionally along the roadway, with only two movements: forward and turning, and could not move backward. The simulation environment is shown in Figure 25, where a total of 7 navigation waypoints, a~h, were set in the entire environment. Table 5 shows the coordinates of each navigation waypoint except for starting point a.
Figure 25.
Schematic diagram of the tunnel simulation test environment and area. In the figure, the red star marks the starting point, the purple circle represents the via point, and the yellow star denotes the destination.
Table 5.
Coordinates of navigation waypoints.
Figure 26 shows the comparison diagram of the full navigation trajectories of the two methods, where the blue dashed line is the navigation trajectory based on the Bézier curve, and the orange solid line is the navigation trajectory based on the cubic spline curve. Since the speeds set in the experiment are the same and the positions of the navigation points are consistent, the execution times of the two offline trajectory libraries are almost the same, both around 158 s. Among them, the total navigation distance using the offline trajectory library generated based on the Bézier curve is 291.665 m, and the total navigation distance using the offline trajectory library generated based on the cubic spline curve is 292.164 m. It can be seen from the figure that a total of four turns were experienced during the entire navigation process, among which the first and last two are right-angle turns, and the middle two are obtuse-angle turns. The trajectories of three regions were selected for specific analysis. Region A is the first right-angle turn. Before entering the turn, the two trajectories have almost no difference, both walking along the center of the roadway. After turning, the trajectory based on the cubic spline curve has obvious jitter, while the trajectory based on the Bézier curve can move forward with a smooth trajectory. Region B is the second turn. Before entering the turn, the trajectory based on the cubic spline curve also has obvious jitter, while the trajectory based on the Bézier curve is very smooth before and after entering the turn. Region C is the last right-angle turn but includes two consecutive steering adjustments. Both trajectories are very smooth, and the trajectory based on the Bézier curve is closer to the turning side than that based on the cubic spline curve.
Figure 26.
Comparison diagram of navigation trajectories in the tunnel environment. (A) Passing through a right-angle bend; (B) Passing through an obtuse-angle bend; (C) Passing through continuous curves.
Figure 27 shows the comparison of simulation experiments during continuous turning in Region B of the above figure. It can be seen from the figure that during the first turn entry, both methods have more path choices. However, when entering the second turn, only a few sub-paths of one sub-path bundle remain executable in the offline trajectory library based on the cubic spline curve, while the offline trajectory library based on the Bézier curve has additional and denser path choices.
Figure 27.
Comparison diagram of continuous turning experiments in region B of the tunnel environment. (a) Autonomous obstacle avoidance and turning based on a cubic spline curve. (b) Autonomous obstacle avoidance and turning based on a Bézier curve. The purple spheres denote navigation target points, and the axes Red (x), Green (y), Blue (z) in the figure correspond to the robot base coordinate system.
Comprehensive analysis of the above experimental results shows that due to the overly discrete path directions and angles selectable in the initial state of the offline trajectory library based on the cubic spline curve, multiple adjustments are required in a certain area before and after turning to enter and exit the turn. In contrast, the initial state sampling of the offline trajectory library based on the Bézier curve is more uniform, so it has more selectable paths and steering angles, and can perform attitude adjustment more smoothly during navigation.
- (2)
- Comparison with 2D map-based method
To further verify the feasibility, planning speed, robustness, and other indicators of the algorithm, a simulated roadway environment, as shown in Figure 28, was built in the Gazebo simulation platform. This environment consists of multiple sections. We adopted different scenarios to compare the performance between the proposed method and the hybrid A* algorithm using 2D maps.
Figure 28.
Gazebo model of simulated roadway.
In Figure 29, the left side shows the planning effect of the hybrid A* algorithm in the environment, and the right side presents the planning effect of the algorithm proposed in this paper. This environment is used to test the performance of algorithms when exploring scenarios with long-distance right-angle bends. The hybrid A* algorithm yields a search path length of 122.2 m with a search time consumption of 10.5 s, while the method in this paper achieves a search path length of 115.4 m and a search time consumption of 330 μs. The trajectory in the left figure exhibits a typical wavy shape within the straight roadway, which is caused by frequent trajectory adjustments of the robot. At the position marked by the red circle in the left figure, the trajectory navigates the right-angle bend by reversing first and then moving forward. This turning trajectory, combined with Reed–Shepp curves, performs well in certain application scenarios, yet such a turning pattern is unnecessary for roadways in coal mines. By contrast, the trajectory in the right figure bypasses this reversing maneuver and passes through the right-angle bend with a direct turn. Furthermore, the straightness of the path within the roadway generated by the proposed algorithm outperforms that of the search path from the hybrid A* algorithm shown on the left.
Figure 29.
Comparison diagram of the hybrid A* algorithm and our method under Scenario 1. (a) Experimental results of the hybrid A*, the green lines represent the robot’s motion trajectories. (b) Experimental results of our method, yellow lines in front of the robot are traversable paths, purple sphere represents navigation target point, the rainbow-colored lines denote the robot’s motion trajectories The axes Red (x), Green (y), Blue (z) in the right figure correspond to the robot base coordinate system.
The upper and lower diagrams in Figure 30 correspond to the planning results of the hybrid A* algorithm and the algorithm proposed in this paper, respectively. This environment is used to test the performance of the algorithms when planning paths through spaces with Z-shaped right-angle bends and narrow tunnels. In this search experiment, the hybrid A* algorithm generated a search trajectory with a length of 167.4 m and took 18.7 s for computation. By contrast, the method proposed in this paper produced a search trajectory of 152.3 m with a computation time of only 340 μs. The two diagrams show similar performance in the initial straight path segment. However, once the robot enters the narrow tunnel with multiple right-angle bends (the tunnel width is 2.2 m), the areas marked by red circles in the left diagram reveal unnecessary pose adjustments. Specifically, when navigating Z-shaped right-angle bends, the hybrid A* algorithm fails to find a direct turning path. In comparison, the algorithm from this paper achieves superior performance when passing through Z-shaped right-angle bends. After the robot exits the narrow tunnel and moves into open space, the hybrid A* algorithm in the left diagram makes unnecessary S-shaped detours, and redundant pose adjustments are also required upon reaching the target, which results in extra time consumption. Under the same environmental conditions, the algorithm proposed in this paper delivers higher path search efficiency, as well as improved path feasibility and stability relative to the hybrid A* algorithm. Although the proposed algorithm can smoothly traverse all bends, it occasionally follows paths that fit excessively close to the bend corners.
Figure 30.
Comparison diagram of the hybrid A* algorithm and our method under Scenario 2. (a) Experimental results of hybrid A*, the green lines represent the robot’s motion trajectories. (b) Experimental results of our method, yellow lines in front of the robot are traversable paths, purple sphere represents navigation target point, the rainbow-colored lines denote the robot’s motion trajectories. The axes Red (x), Green (y), Blue (z) in the figure correspond to the robot base coordinate system.
4.2. Ground Simulation Roadway Field Experiments
To verify the stability and generalization of the autonomous navigation system, ground field experiments were conducted on both types of models. Model A was tested for continuous autonomous walking and fixed-point parking, while Model B was tested for autonomous navigation obstacle avoidance, fixed-point parking in 2D maps, and precise drilling in the ground simulation roadway.
4.2.1. Autonomous Walking and Fixed-Point Parking Experiment
The experiment of continuous autonomous walking and fixed-point parking was tested on Model A. The parking points and measured position data are shown in Table 6. Since the data of the positioning algorithm change in real time when the robot is moving, the set target point is a circular area with a diameter rather than a single point. If the arrival area is set too small (<Φ 0.1 m), the robot will always be unable to reach the target point and make peristaltic adjustments, which is undoubtedly very dangerous for large machinery. Therefore, to ensure safety, after multiple tests, we finally set the arrival threshold to Φ 0.2 m, which was followed in all subsequent experiments. The maximum walking speed of the robot was set to 0.175 m/s. After navigating to the target point, it is necessary to perform 5 drilling rig actions: drill bit attitude adjustment, drill feeding, drilling, drill withdrawal, and drill bit reset, and then continue autonomous navigation according to the preset parking point (drilling rig working position). The actual distance in Table 5 is the relative distance difference between the set value of the target point and the parking position (actual value) measured by the laser odometer.
Table 6.
Set values and actual values of fixed-point parking target points for drilling positions in experiment 1.
During the initialization phase, the drilling robot navigation system loads paths and adjacency lists into the computer memory. The processing time of the on-board system is presented in Table 7. In the collision detection stage, data points from all perception sensors are first processed to filter out collision-free paths, with an average processing time of 178.4 μs. Next, all paths are traversed to calculate for each path group, and the group with the maximum value is selected. This step takes an average of 22.3 μs. The proposed method runs at 10 Hz, and the single-thread CPU usage is kept below 5% in the experiment. Since the two robots adopt identical computing hardware configurations, the running speeds of the algorithms are nearly the same.
Table 7.
Online processing time in the experiment.
Figure 31 shows the on-site diagram of the drilling robot’s autonomous walking and fixed-point parking experiment. Measured by the EVO toolbox, the drilling robot traveled a total of 27.261 m, and the total execution time of the entire navigation–drilling–drill withdrawal process was 419 s. It can be seen from the figure that the robot navigation system can form a closed loop of continuous autonomous walking, parking, and autonomous walking. Figure 32 shows its positioning data on the X-axis, indicating that the robot can park accurately at the relevant position. The robot can park within the arrival threshold with an average error of 0.1625 m. Compared with small robots, this parking distance error may be too conservative, but for large-scale production machinery, safety is the primary principle. Of course, the accumulated error in motion control can be corrected through mechanical adjustment of the drill bit, which can be specifically seen in Section 4.2.4.
Figure 31.
On-site diagram of the drilling robot’s autonomous walking and fixed-point parking experiment: (a) start navigation; (b) arrive at the first target point; (c) perform drilling operation at the first hole position; (d) second target point; (e) perform drilling operation at the second hole position; (f) navigate to the third target point; (g) adjust the drill bit position; (h) navigate to the fourth target point; (i) complete navigation. In the figure, the robot model is rendered in gray, yellow lines in front of the robot are traversable paths, red lines behind robot denote traveled trajectories, purple sphere represents navigation target point. In the environment, the colored point clouds transition from red to purple, corresponding to point cloud heights from low to high.
Figure 32.
X-axis trajectory diagram of the drilling robot’s fixed-point parking experiment. The dashed lines represent the 5-meter reference lines.
4.2.2. Autonomous Walking and Obstacle Avoidance Experiment in L-Shaped Roadway
The autonomous walking functions, such as turning and obstacle avoidance, of the drilling robot’s autonomous navigation system, were tested in the L-shaped roadway. Figure 33 shows the on-site of the autonomous navigation experiment in the L-shaped roadway and the direction that the drilling robot needs to walk for the autonomous walking and obstacle avoidance test. The maximum walking speed of the robot was set to 0.175 m/s. Due to the self-weight of the drilling robot reaching 8.3 t, wooden boards were laid on the road to prevent road damage. This also has an adverse effect of slippage on the robot’s navigation and walking, and at the same time, brings certain challenges to the autonomous navigation system of the drilling robot, which can be used to verify the robustness and stability of the navigation system under slippage conditions.
Figure 33.
On-site of the autonomous navigation experiment in the L-shaped roadway.
Figure 34 shows the entire process of the autonomous navigation experiment in the L-shaped roadway. The lower right corner of each navigation interface is the actual on-site picture of the robot in the simulated roadway. Measured by the EVO toolbox, the robot traveled a total of 15.593 m during the entire navigation process. Figure 34a shows the initial state of navigation. To ensure the safety of the drilling robot and on-site staff, manual target point setting was adopted throughout the process for real-time navigation and obstacle avoidance. A total of four target points were set in the experiment. The first target point was set not far directly in front of the starting point, and the robot could realize normal autonomous walking along the optimal path in the offline lookup table; the second target point was set as the robot’s left-turn target point. It can be seen from Figure 34b,c that the robot has started to turn, moved close to the side wall of the roadway, and always maintained a safe distance from the roadway wall without collision; the third target point was used to adjust the robot’s forward attitude after the robot completed the turn. As shown in Figure 34d, due to ground slippage, the robot did not quickly adjust to the attitude aligned with the roadway after turning; after setting the fourth target point, the robot could quickly adjust its attitude, move away from the roadway wall, and finally reach the target point, which indicates that the autonomous navigation system can ensure the movement safety of the robot under slippage conditions.
Figure 34.
Navigation interface and on-site of the autonomous navigation experiment in the L-shaped roadway: (a) start from the initial position; (b) start turning; (c) turning in progress; (d) complete the turn; (e) drive straight; (f) complete navigation. In the figure, the robot model is rendered in gray, yellow lines in front of the robot are traversable paths, red lines behind robot denote traveled trajectories, purple sphere represents navigation target point. In the environment, the colored point clouds transition from red to purple, corresponding to point cloud heights from low to high.
4.2.3. Fixed-Point Parking Experiment in 2D Maps
To compare the advantages of our proposed method with traditional 2D map-based navigation methods, we tested a classic 2D map navigation architecture on the autonomous navigation system of the drilling robot. This architecture combines the hybrid A* global path planning method and the MPC trajectory tracking control method. Meanwhile, a bounding box-based collision detection method and an inflated map were adopted to prevent the drilling robot from colliding with the tunnel walls. Since no surveying instruments were available, a relative positioning accuracy test was conducted in the 2D map navigation experiment. Parking spots were marked with lines on the ground. When the robot reached a parking spot, a straight edge was used to mark the position for measuring the robot’s motion accuracy, and a 2D LiDAR odometer recorded the robot’s parking position in the algorithm. In the experiment, the upper computer sent four target points (as shown in Table 8) to the drilling robot, with a vertical linear distance of 1.5 m between adjacent points. The parking duration was set to 40 s. After the robot arrived at each parking position, testers placed wooden boards vertically behind the tracks on both sides and drew parking lines at the designated spots. Finally, a laser rangefinder was used to measure the actual spacing between each parking line to verify the performance of the motion planning algorithm. As the arrival threshold was defined as a parking range, the arrival distance in the table refers to the deviation between the odometer reading when the robot stopped and the preset value of the parking point, which reflects the parking accuracy of the robot.
Table 8.
Set values and actual values of fixed-point parking target points for drilling positions in experiment 2.
Figure 35 shows the on-site scene and navigation interface of the linear fixed-point parking test for the drilling robot based on a two-dimensional map. It can be seen from the figure that the staff drew lines behind the robot to record its parking position each time it stops. The robot can perform continuous parking maneuvers in the simulated roadway, and neither the robot nor its bounding box collides with the roadway. Although the robot maintains a tendency to move in a straight line, positioning drift occurs due to map degradation during movement. Since hybrid A* is direction-aware, the robot deviates noticeably by a certain angle at the parking position, which poses a serious safety hazard in real roadway environments.
Figure 35.
On-site linear fixed-point parking test with 2D map and navigation interface of the drilling robot: (a) start position; (b) arrive at the first target point; (c) arrive at the second target point; (d) arrive at the third target point. The robot model is rendered in gray. The green rectangular boxes are the collision avoidance bounding boxes of the robot, black areas signify environmental obstacles, and gray zones represent safety inflation regions.
4.2.4. Precise Drilling Experiment in T-Shaped Roadway
The on-site layout of the precise drilling experiment of the drilling robot in the T-shaped roadway is shown in Figure 36. Two circular holes for testing comprehensive control accuracy were opened on the wall of the simulated roadway, and the relative positions between the circular holes are shown in the figure. The experiment adopted the relative positioning accuracy method for testing, and the precise drilling experiment mainly tested the combined control accuracy of the drilling robot (drilling positioning accuracy + motion control accuracy). Two fixed parking points were given to the drilling robot. To simplify the debugging steps, the given parking point coordinates were the robot’s rotation center position, which only had a translational coordinate transformation relationship with the drilling position, and rotational transformation was not considered. Two circular holes with a diameter of 40 cm were drilled into the wall, and a comprehensive positioning accuracy error range of ±20 cm was set; a parking area was set on the ground and marked with lines. When reaching the parking position set by the autonomous navigation system, the robot was lifted by the hydraulic support, and then drilling operations were performed. The drill bit control algorithm of the drilling robot was provided by the Xi’an Research Institute of CCTEG and installed in the main control computer. The position where the drilling robot extends the drill pipe at this time can intuitively show the comprehensive positioning accuracy of the drilling robot and can also indirectly test the motion control accuracy of the autonomous navigation system. The fixed-point parking coordinate values of the drilling robot in this experiment are shown in Table 9. The robot’s main control set two target points, and it can be seen that the robot can park within the arrival threshold with an average error of 0.1475 m.
Figure 36.
Experiment environment and on-site layout of the drilling robot’s precise drilling.
Table 9.
Set values and actual values of fixed-point parking target points for drilling positions in experiment 3.
Figure 37 shows the on-site live scenes and navigation interface of the drilling robot’s precise drilling experiment. Measured by the EVO toolbox, the drilling robot traveled a total of 11.919 m, and the total execution time of the entire process was 591 s. Compared with Model A, Model B had additional steps of hydraulic support lifting and retracting, so it took a longer time. Figure 37b,d show the actual position of the drill pipe within the preset area when the robot was drilling, indicating that the drill pipe of the drilling robot could be accurately controlled within the circular area with a diameter of 40 cm. Figure 37g shows that the robot could walk along a straight line in this experiment without obvious slippage and deviation, and the entire navigation process could be carried out completely according to the work requirements, and could be effectively connected with the subsequent drill feeding and drill withdrawal actions, so that navigation work could continue after the drilling robot completed drill withdrawal. The above experiments verified the effectiveness of the drilling robot’s navigation system in the entire working process of the drilling robot. Figure 38a and Figure 38b, respectively, show the on-site comparison between the parking position of the robot and the reference position at the first drilling position and the second drilling position. It can be seen that the drilling robot can accurately stop within the expected position area. Compared with the 2D map-based navigation method described in Section 4.2.3, the trajectory generated by our method enables the robot to park almost parallel to the roadway, thus ensuring the safety of both the robot and staff working in the roadway. Moreover, by comparing Table 8 and Table 9, it can also be seen that the method proposed in this paper outperforms the hybrid A* method based on 2D maps in terms of average parking error.
Figure 37.
On-site photos of precise drilling experiments and navigation interface of the drilling robot system: (a) arrive at the first target point; (b) drilling accuracy display of the first hole position; (c) arrive at the second target point; (d) drilling accuracy display of the second hole position; (e) navigation interface upon arrival at the first target point; (f) navigation interface upon arrival at the second target point; (g) top view of navigation trajectory; (h) rear view of navigation trajectory. In the figure, the robot model is rendered in gray, red lines behind robot denote traveled trajectories, purple sphere represents navigation target point. In the environment, the colored point clouds transition from red to purple, corresponding to point cloud heights from low to high.
Figure 38.
On-site comparison of the parking position of the robot: (a) actual parking position of the first target point; (b) actual parking position of the second target point.
4.3. Underground Coal Mine Field Experiments
Bulleted lists look like this: The underground field experiments were carried out in Shoushan No. 1 Mine of Pingbao Coal Industry Co., Ltd., and Pingdingshan Tianan Coal Industry Co., Ltd., to test the autonomous navigation system in the actual underground environment. The on-site test environment was in a standby ventilation roadway of the coal mine, with a roadway width of 5.2 m, a height of 4.2 m, a straight line plus arc structure, a walkable length of about 30 m, a mine car track in the middle of the ground, and a monorail crane track installed on the top. Figure 39 shows the test environment during the on-site application test at the underground and debugging sites.
Figure 39.
On-site test environment of the underground coal mine and debugging site.
Due to the limitations of the on-site roadway size, the motion platform finally adopted by the autonomous navigation system was the crawler-type full-hydraulic drilling robot for coal mines (Model B), developed by the Xi’an Research Institute Co., Ltd. of CCTEG (Xi’an, China); the control system was the ZJQR-4000 main control and management system for coal mine drilling robots developed by the Chongqing Research Institute of CCTEG, which was used to realize data communication between the navigation system and the drilling robot’s own motion control system. The test upper computer adopted an intrinsically safe laptop and a MESH wireless communication module.
The set values of the target points of the autonomous navigation experiment and the actual parking point coordinates measured by the laser odometer are shown in Table 10. The maximum linear speed of the drilling robot was set to 0.175 m/s, and two target points were set. It can be seen that the drilling robot could park within the arrival threshold with an average error of 0.1425 m.
Table 10.
Set and actual values of navigation target points in underground field experiments.
Figure 40 shows the on-site live scenes and navigation interface of the underground autonomous navigation experiment. Measured by the EVO toolbox, the total travel distance of the drilling robot was 17.312 m, and the total execution time of the entire navigation–drilling–drill withdrawal process was 346.1 s. During the entire navigation process, the robot experienced 2 parking drilling operations and 1 autonomous obstacle avoidance behavior. It can be seen from Figure 40c,d that the robot could actively avoid the drill pipe box placed on the left side of the robot and then continue to move forward to the second target point for operation. This experiment also verified that the autonomous navigation system of the drilling robot proposed in this paper can work in the actual underground coal mine, can accurately control the autonomous walking and obstacle avoidance of the drilling robot, and can meet the on-site application requirements of the drilling robot.
Figure 40.
On-site pictures and navigation interface of the underground autonomous navigation experiment: (a) reach the first target point; (b) drill at the first hole position; (c) perform autonomous obstacle avoidance; (d) complete autonomous obstacle avoidance; (e) reach the second target point; (f) drill at the second vacant position. In the figure, the robot model is rendered in gray, red lines behind robot denote traveled trajectories, purple sphere represents navigation target point. In the environment, the colored point clouds transition from red to purple, corresponding to point cloud heights from low to high.
5. Conclusions
This paper focuses on key autonomous navigation technologies of coal mine drilling robots in unstructured underground environments, completing the design, development, and experimental verification of an autonomous navigation system. The main conclusions are summarized as follows:
- (1)
- A hardware system suitable for underground coal mine environments is constructed. Industrial-grade components are selected to adapt to harsh underground conditions, with the main electrical equipment integrated into an explosion-proof electric control box. A digitally modeled sensor bracket ensures a reasonable layout of lidar, UWB antennas, and explosion-proof cameras, and the Nuvo-5095 GC industrial computer stably processes laser point cloud data and navigation algorithms.
- (2)
- A complete software system was developed. Adopting the ROS robot operating system architecture and ZJQR-4000 main control system as the interface, it realizes communication with the drilling robot’s PLC. Designed navigation module data formats ensure effective transmission, with Python-based communication nodes enabling real-time data interaction and a Qt5-based monitoring interface displaying navigation and robot status.
- (3)
- An autonomous obstacle avoidance method for unstructured underground terrain is proposed. Based on 3D lidar point clouds, the terrain analysis module segments feasible regions. The maximum arrival probability-based path planning, Bézier curve-based trajectory library with superior efficiency, and optimal path selection rules ensure smooth and safe robot movement.
- (4)
- Three types of experiments validate the system’s effectiveness and robustness. Simulation experiments show that Bézier curve-based trajectories are smoother than cubic spline curves. Ground and underground experiments demonstrate stable performance, with average parking errors of 0.1475, 0.1625 m, and 0.1425 m, respectively, meeting on-site application requirements.
This study first constructs a full set of autonomous navigation systems for large-scale underground coal mine drilling robots, breaking through the technical bottleneck of autonomous locomotion for drilling robots in unstructured environments. However, limitations remain: the offline trajectory library requires pre-generation, which imposes constraints on adaptability to highly dynamic environments, while navigation accuracy can be further improved for extremely complex terrain. Future work will focus on optimizing the real-time performance of the obstacle avoidance algorithm, enhancing the adaptability of the trajectory library to dynamic environments, and integrating more advanced sensor fusion technologies to further improve the stability and accuracy of the autonomous navigation system, thereby promoting the large-scale application of intelligent drilling robots in coal mines.
Author Contributions
Conceptualization, S.Y. and M.L.; methodology, S.Y.; software, S.Y.; validation, S.Y., M.L., and C.T.; formal analysis, M.L.; investigation, J.W.; resources, J.W.; data curation, C.T.; writing—original draft preparation, S.Y.; writing—review and editing, M.L.; visualization, M.L.; supervision, M.L.; project administration, J.W.; funding acquisition, S.Y. and M.L. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the National Natural Science Foundation of China (grant number: 52504178, 52304183), the National Key Research and Development Program of China (grant number: 2024YFB2908801), and, in part, by the Project Funds of the Priority Academic Program Development (PAPD) of Jiangsu Higher Education Institutions.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The datasets presented in this article are not readily available because of time and experimental site environment limitations. Requests to access the datasets should be directed to the author at youshaoze@cumt.edu.cn.
Conflicts of Interest
The authors declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| CCTEG | China Coal Technology and Engineering Group |
| SLAM | Simultaneous Localization and Mapping |
| DWA | Dynamic Window Approach |
| UAV | Unmanned Aerial Vehicles |
| 2D | Two-dimensional |
| 3D | Three-dimensional |
| ROS | Robot Operating System |
| MPC | Model Predictive Control |
| UWB | Ultra-Wide Band |
| CPU | Central Processing Unit |
| GPU | Graphics Processing Unit |
| NVME | Non-Volatile Memory Express |
| PLC | Programmable Logic Controller |
| IPC | Industrial Personal Computer |
| GIS | Geographic Information System |
| UDP | User Datagram Protocol |
| JSON | JavaScript Object Notation |
| QP | Quadratic Programming |
References
- Niu, H.; Zhu, H.; Wang, G.; Pan, H.; Sun, S.; Yu, X.; Yang, X.; He, J. A review of the mechanisms and control technologies of coal and gas outbursts: Recent advances and future perspectives. Energy Fuels 2024, 38, 23230–23245. [Google Scholar] [CrossRef] [Scilit]
- Al-Chalabi, H.; Lundberg, J.; Jonsson, A. Economic lifetime of a drilling machine: A case study on mining industry. Int. J. Strateg. Eng. Asset Manag. 2015, 2, 177–189. [Google Scholar] [CrossRef] [Scilit]
- Baiden, G.; Bissiri, Y.; Luoma, S.; Henrich, G. Mapping utility infrastructure via underground GPS positioning with autonomous telerobotics. Tunn. Undergr. Space Technol. 2014, 39, 6–14. [Google Scholar] [CrossRef] [Scilit]
- Cohen, M.W.; Coelho, V.N. Open-pit mining operational planning using multi agent systems. Procedia Comput. Sci. 2021, 192, 1677–1686. [Google Scholar] [CrossRef] [Scilit]
- Shizhai, Z.; Qingwen, W. Design and key technology research of ZYWL-4000SY remote control drilling rig. Coal Sci. Technol. 2021, 49, 129–134. [Google Scholar] [CrossRef]
- Wang, Q.; Xin, D.; Chen, H. Application of remote control technology in gas drainage drilling rig in coal mine. Proc. J. Phys. Conf. Ser. 2020, 1626, 012078. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z.; Si, L.; Dong, W.; Dai, J.; Gu, J.; Zou, X.; Zhang, C.; Yan, H.; Tan, C. Key technologies of fully autonomous drilling system for coal mine anti-impact drilling robot. J. China Coal Soc. 2024, 49, 1240. [Google Scholar] [CrossRef]
- Zhang, R.; Yao, K.; Fang, P.; Wang, L.; Chen, F.; Chen, X.; Shao, J.; Luo, P.; Wang, S.; Liu, Q. Key technologies for research and development of automatic drilling rig in underground coal mine. Coal Sci. Technol. 2019, 47, 59–63. [Google Scholar] [CrossRef]
- Liu, Z.; Li, Z.; Zou, K.; Xie, C. Research and application of bolter miner airborne drilling rig. Sci. Rep. 2025, 15, 8179. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Li, Q.; Liu, F.; Fang, J. Recent advances in research on intelligent technologies and equipment for underground geological exploration of coal mines in China. Coal Geol. Explor. 2026, 54, 1–14. [Google Scholar] [CrossRef]
- Feng, S.; Hu, J.; Fan, Z.; Ren, J.; Miao, Y.; Hu, J. A New Approach for Real-Time Coal–Rock Identification via Multi-Source Near-Bit Drilling Data. Energies 2026, 19, 1785. [Google Scholar] [CrossRef] [Scilit]
- Cheng, Y.; Han, Z.; Jiao, Y.; Chen, S.; Wang, C. A Borehole Image Dataset for the Intelligent Identification of Structural Planes. Results Eng. 2025, 27, 106419. [Google Scholar] [CrossRef] [Scilit]
- Fang, P.; Yao, K.; Wang, S.; Zhao, L. Development of drilling parameter monitoring system for directional drilling rig in coal mine. Coal Sci. Technol. 2019, 47, 124–130. [Google Scholar] [CrossRef]
- Kang, M.; Hua, D.; Guo, X. Review on the influence of complex stratum on the drilling trajectory of the drilling robot. Appl. Sci. 2023, 13, 2532. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Zhu, H.; You, S.; Tang, C. UWB-based localization system aided with inertial sensor for underground coal mine applications. IEEE Sens. J. 2020, 20, 6652–6669. [Google Scholar] [CrossRef] [Scilit]
- Hu, K.; Li, M.; Jin, Z.; Tang, C.; Hu, E.; Zhou, G. CM-LIUW-Odometry: Robust and High-Precision LiDAR-Inertial-UWB-Wheel Odometry for Extreme Degradation Coal Mine Tunnels. In Proceedings of the 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Hangzhou, China, 19–25 October 2025; pp. 7139–7146. [Google Scholar]
- Yu, Z.; Cao, B.; Fang, X.; Li, M.; Cui, L.; Zhang, C. A Novel Multi-IMU Fusion Positioning Method Using an Adaptive Federated Kalman Filter. IEEE Access 2026, 14, 56584–56596. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Hu, K.; Liu, Y.; Hu, E.; Tang, C.; Zhu, H.; Zhou, G. A multimodal robust simultaneous localization and mapping approach driven by geodesic coordinates for coal mine mobile robots. Remote Sens. 2023, 15, 5093. [Google Scholar] [CrossRef] [Scilit]
- Hu, K.; Li, M.; Jin, Z.; Tang, C.; Hu, E.; Zhou, G. DURAL: Degradation-Resistant Robust Adaptive Localization by LiDAR-Inertial-UWB-Wheel Fusion for Coal Mine Robots. J. Field Robot. 2026, 1–19. [Google Scholar] [CrossRef] [Scilit]
- Chenxuan, H.; Lei, W. Accurate mapping method for under-constrained LiDAR-inertial SLAM system under unstructured influence. COAL Sci. Technol. 2025, 53, 226–240. [Google Scholar] [CrossRef]
- Li, M.; Hu, K.; He, W.; Hu, E.; Tang, C.; Zhou, G. Research on Trajectory Planning and Tracking Methods for Coal Mine Mobile Robots. Appl. Sci. 2023, 13, 9789. [Google Scholar] [CrossRef] [Scilit]
- Konieczna-Fuławka, M.; Koval, A.; Nikolakopoulos, G.; Fumagalli, M.; Santas Moreu, L.; Vigara-Puche, V.; Müller, J.; Prenner, M. Autonomous mobile inspection robots in deep underground mining—The current state of the art and future perspectives. Sensors 2025, 25, 3598. [Google Scholar] [CrossRef] [Scilit]
- Samaei, M.; Faradonbeh, R.S.; Topal, E. A Systematic Review of Path Planning for Mining Fleet Automation: Trends, Challenges, and Future Directions. Min. Metall. Explor. 2026, 1–33. [Google Scholar] [CrossRef] [Scilit]
- Yang, C.; Zhang, X. Key Technologies of Environment Perception and Path Planning for Coal Mine Robots. J. China Coal Soc. 2022, 47, 2844–2872. [Google Scholar] [CrossRef]
- Dai, J.; Chai, Y.; Xiong, P. Path Planning of Underground Robots via Improved A* and Dynamic Window Approach. Appl. Sci. 2025, 15, 6953. [Google Scholar] [CrossRef] [Scilit]
- Kang, K.; Huang, H.; Su, Z.; Wang, H. The Improved Informed-RRT* Algorithm, Which Optimizes the Sampling Strategy and Integrates an Artificial Potential Field. J. Field Robot. 2025, 42, 4033–4052. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Xu, Z.; Liu, H.; Zhu, X.; Lan, B. An Improved Hybrid Ant Colony Optimization and Genetic Algorithm for Multi-Map Path Planning of Rescuing Robots in Mine Disaster Scenario. Machines 2025, 13, 474. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Wu, S.; Liu, H.; Zhu, X.; Lan, B. Improved A* Algorithm-Based Optimal Path Planning of Rescue Robots Within Multi-Environment Maps. Machines 2025, 13, 1099. [Google Scholar] [CrossRef] [Scilit]
- Fu, S.; Lin, C.; Yao, Z.; Lin, T.; Chen, Q. Obstacle-avoidance trajectory planning method for excavators in confined spaces based on improved RRT* algorithm. Sci. Rep. 2026, 16, 2206. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.; Zhang, X.; Yang, W.; Zhang, G.; Wan, J.; Lei, M.; Dong, Z. Safe path planning method based on collision prediction for robotic roadheader in narrow tunnels. Mathematics 2025, 13, 522. [Google Scholar] [CrossRef] [Scilit]
- Essien, E.; Frimpong, S. Enhancing autonomous truck navigation in underground mines: A review of 3D object detection systems, challenges, and future trends. Drones 2025, 9, 433. [Google Scholar] [CrossRef] [Scilit]
- Gao, F.; Wu, W.; Gao, W.; Shen, S. Flying on point clouds: Online trajectory generation and autonomous navigation for quadrotors in cluttered environments. J. Field Robot. 2019, 36, 710–733. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Hu, C.; Chadha, R.G.; Singh, S. Falco: Fast likelihood-based collision avoidance with extension to human-guided navigation. J. Field Robot. 2020, 37, 1300–1313. [Google Scholar] [CrossRef] [Scilit]
- Dolgov, D.; Thrun, S.; Montemerlo, M.; Diebel, J. Practical search techniques in path planning for autonomous driving. Ann. Arbor. 2008, 1001, 18–80. [Google Scholar]
- Lages, W.F.; Alves, J.A.V. Real-time control of a mobile robot using linearized model predictive control. IFAC Proc. Vol. 2006, 39, 968–973. [Google Scholar] [CrossRef] [Scilit]
- Cao, C.; Zhu, H.; Yang, F.; Xia, Y.; Choset, H.; Oh, J.; Zhang, J. Autonomous exploration development environment and the planning algorithms. In Proceedings of the 2022 International Conference on Robotics and Automation (ICRA), Philadelphia, PA, USA, 23–27 May 2022; pp. 8921–8928. [Google Scholar]
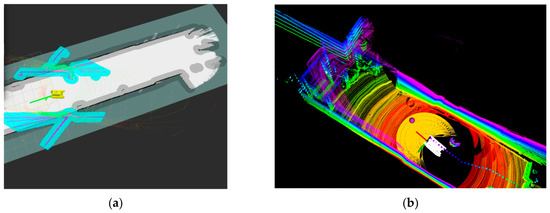
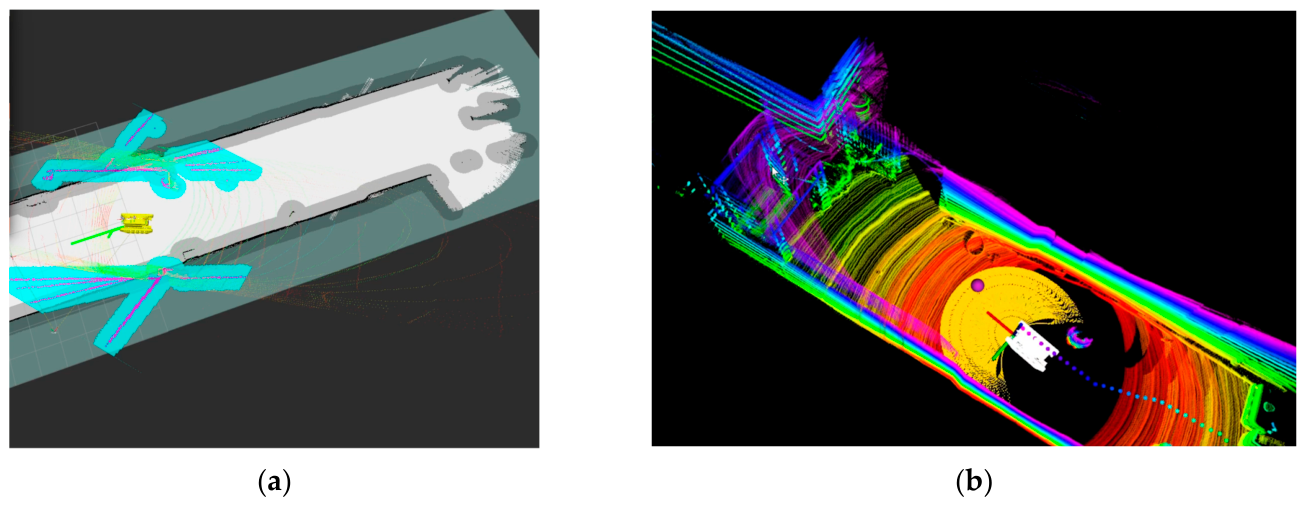
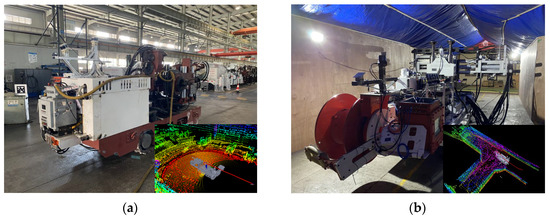
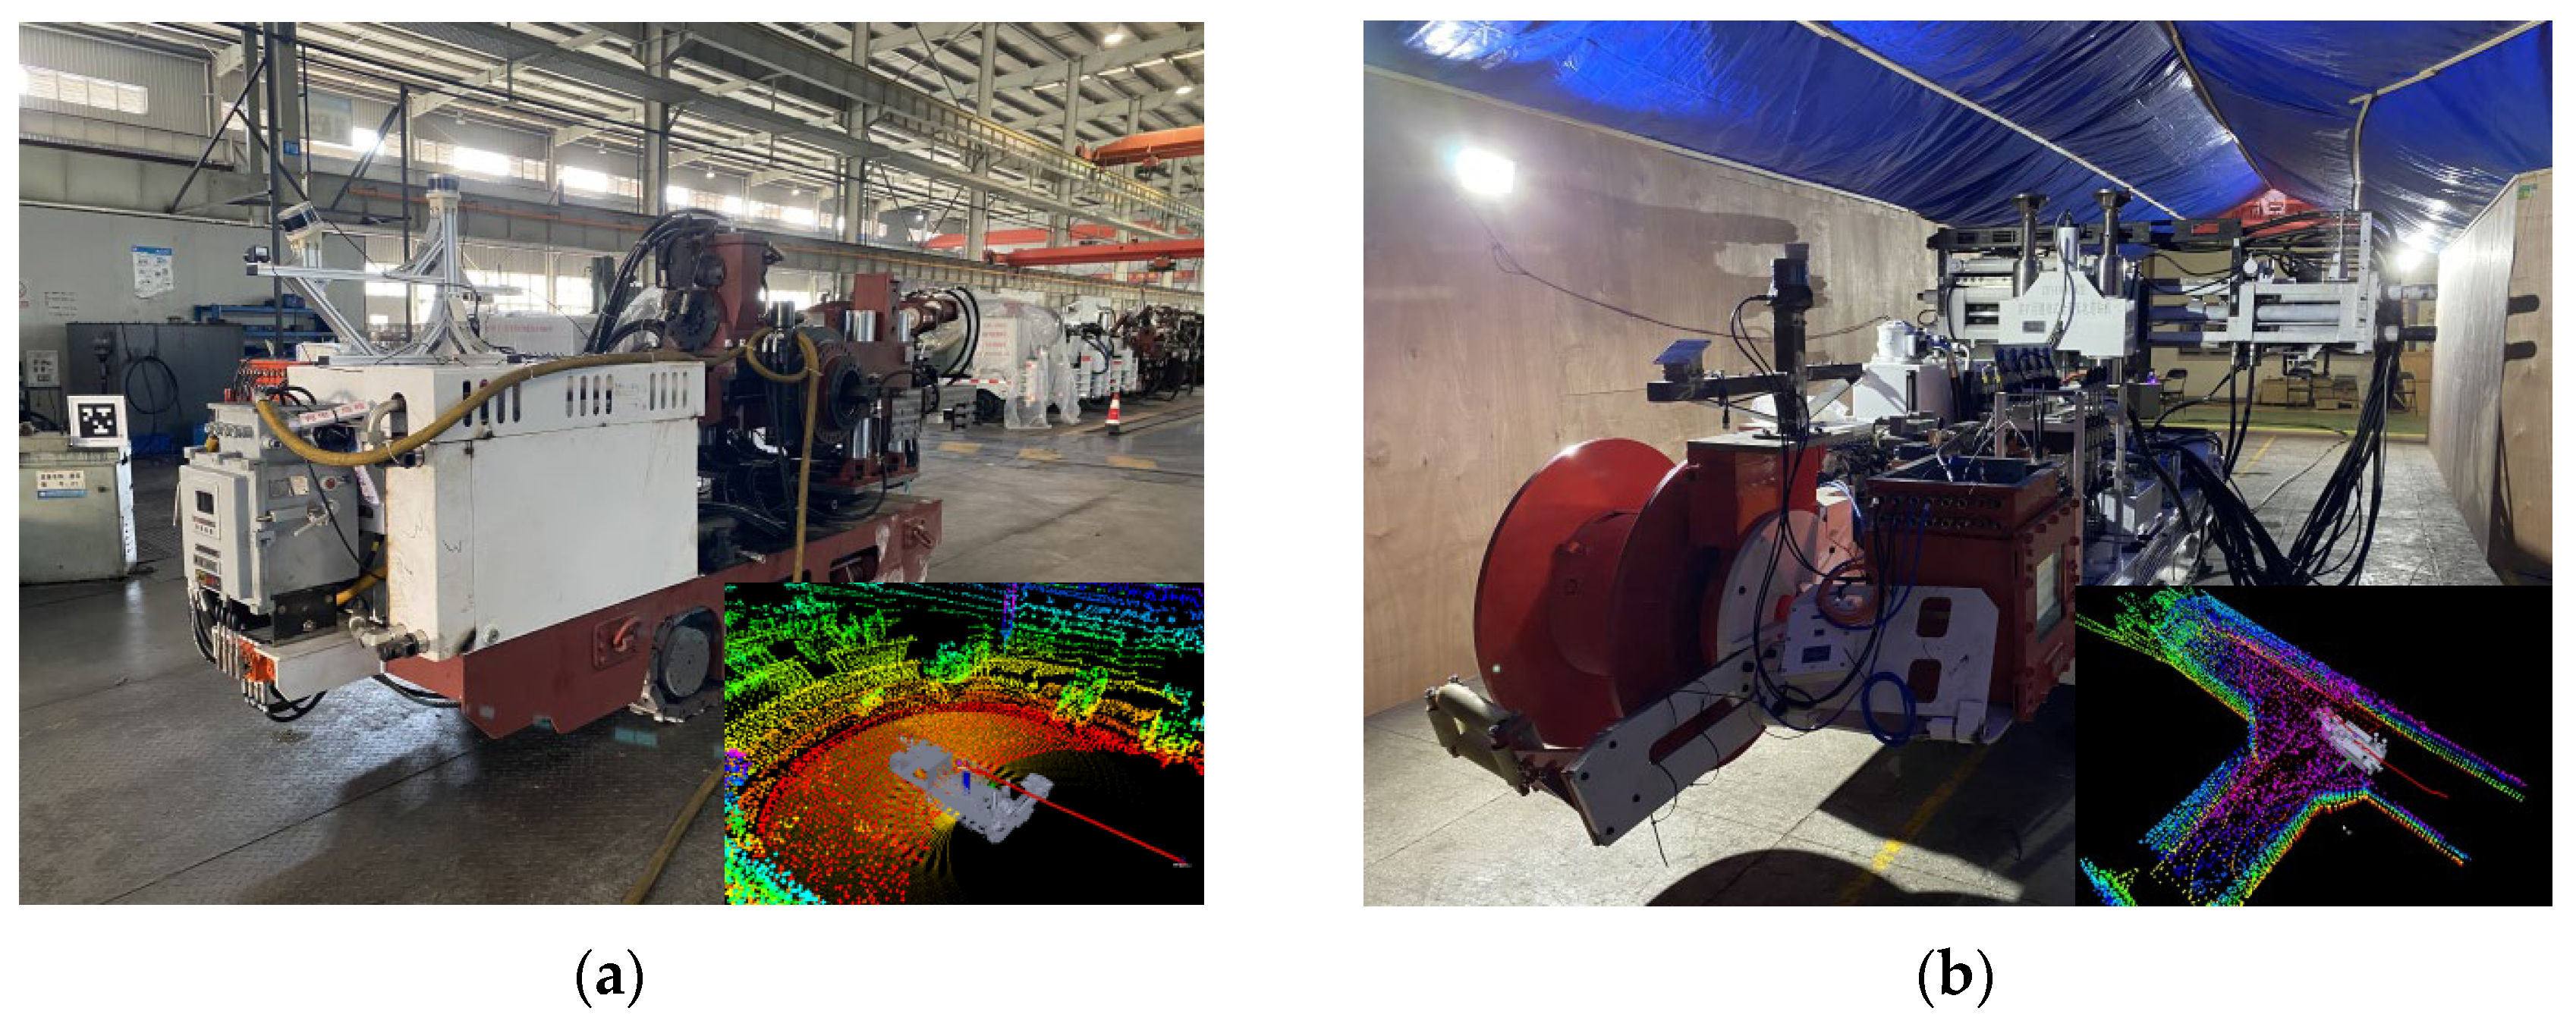
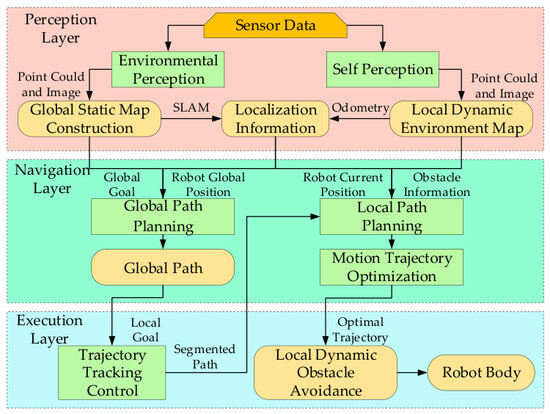
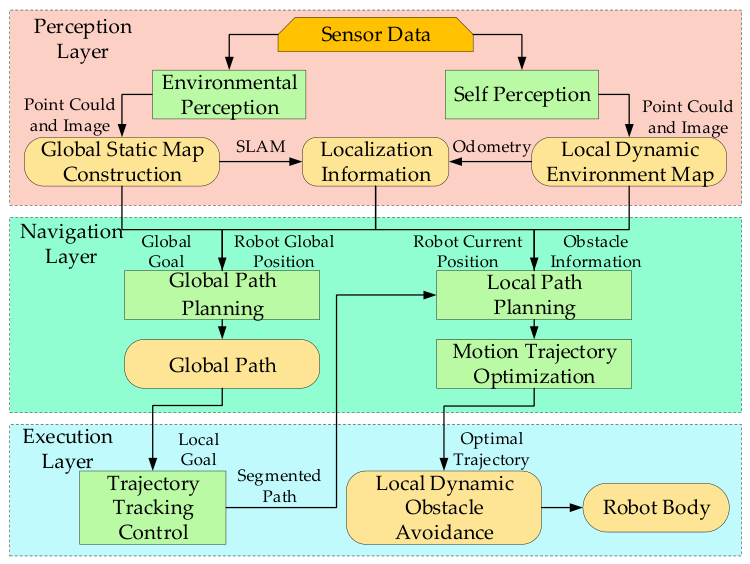
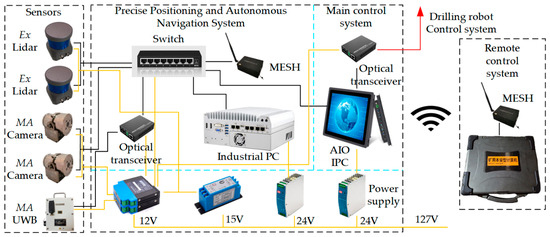
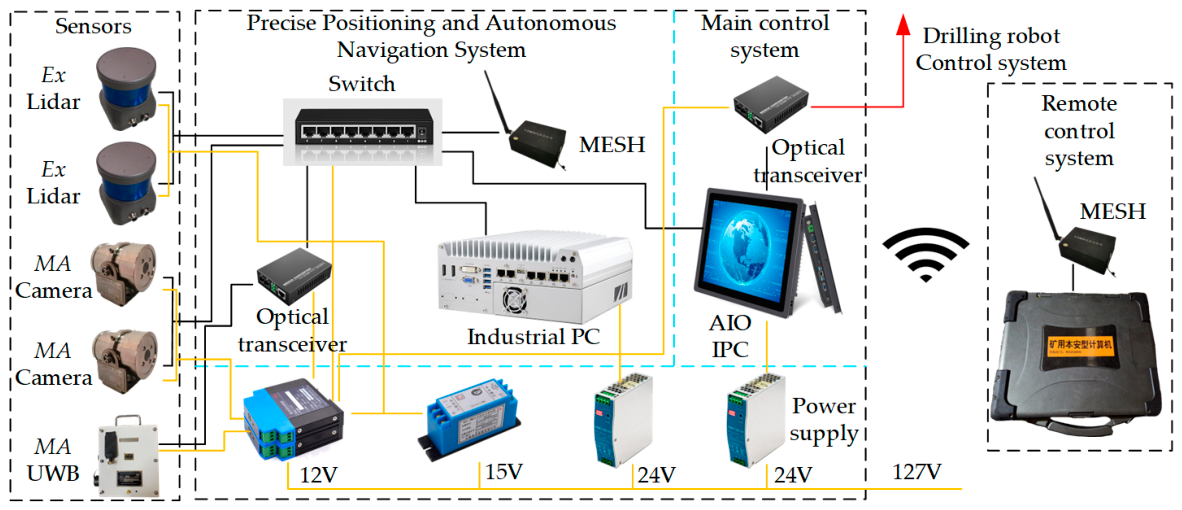
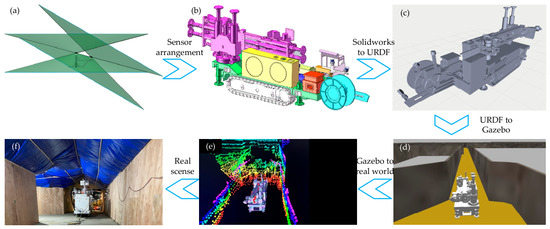
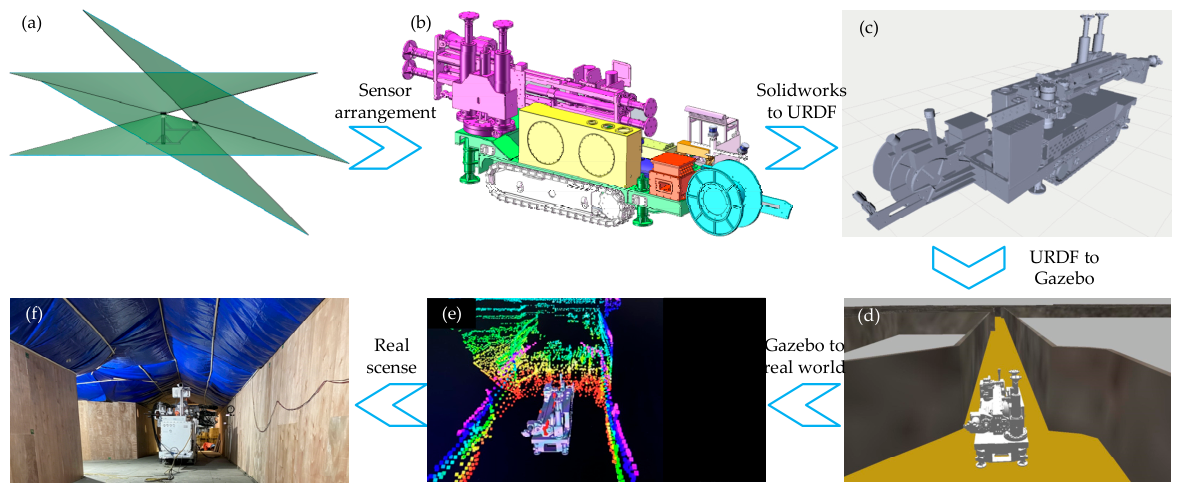
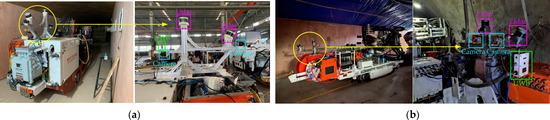
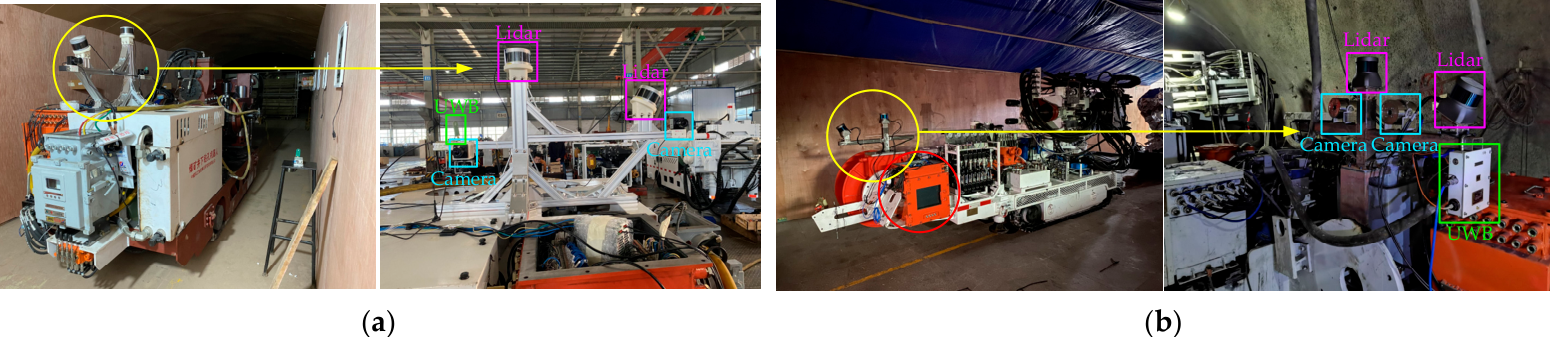
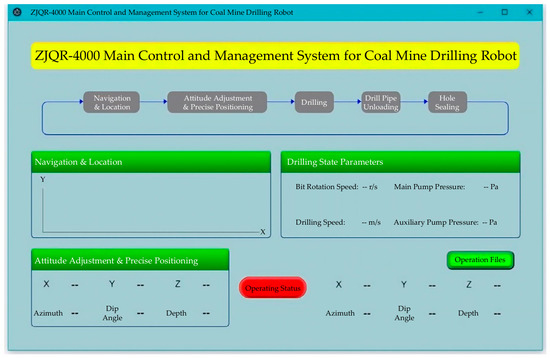
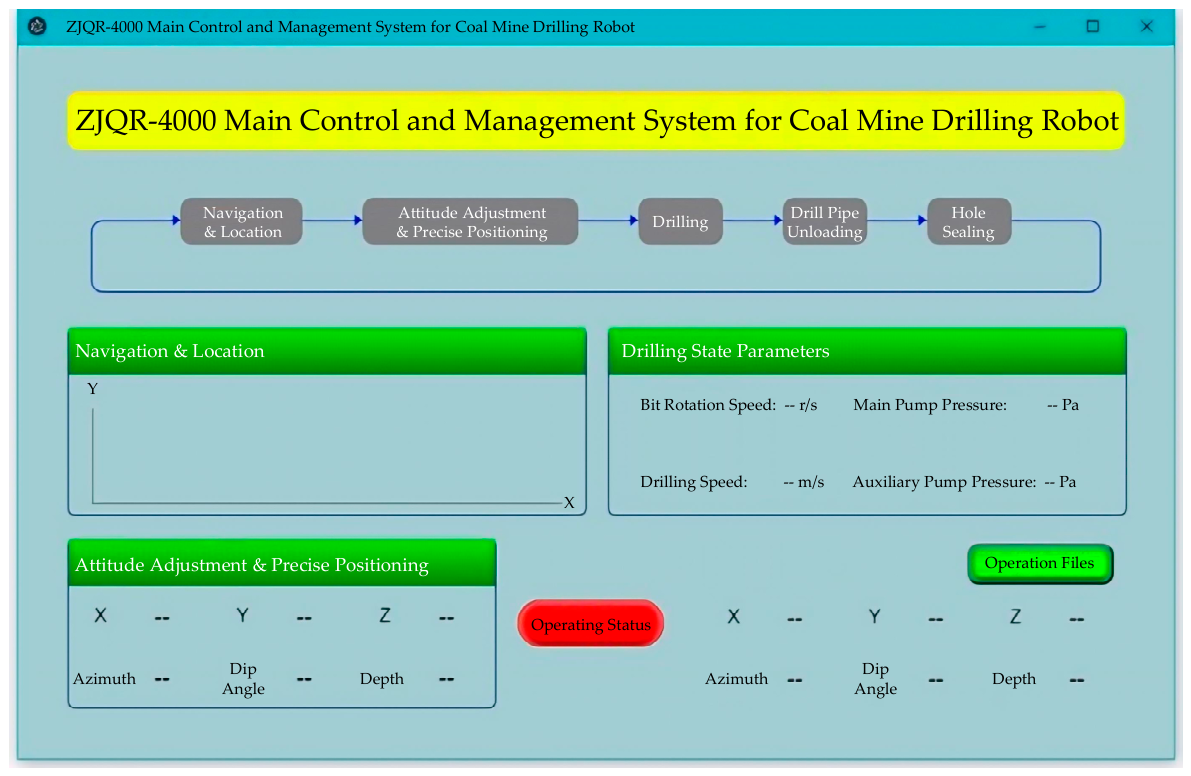
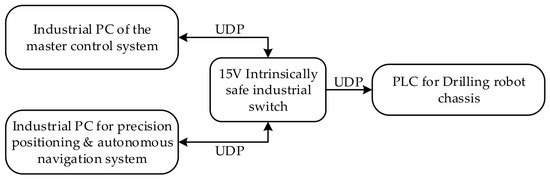
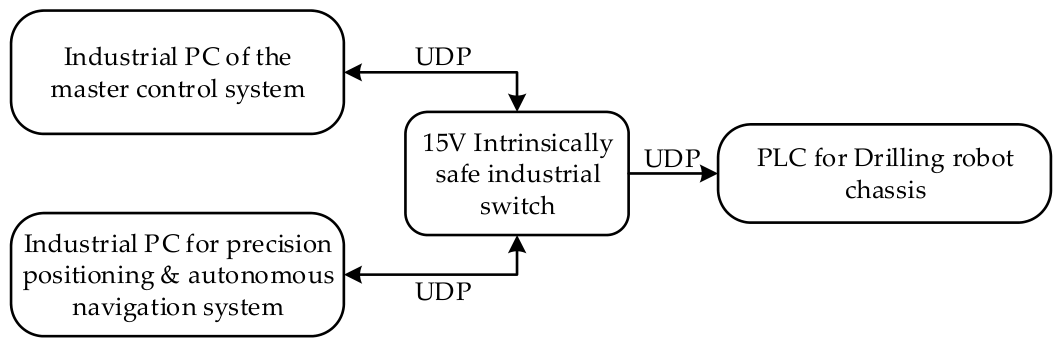
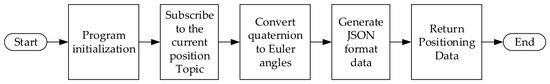
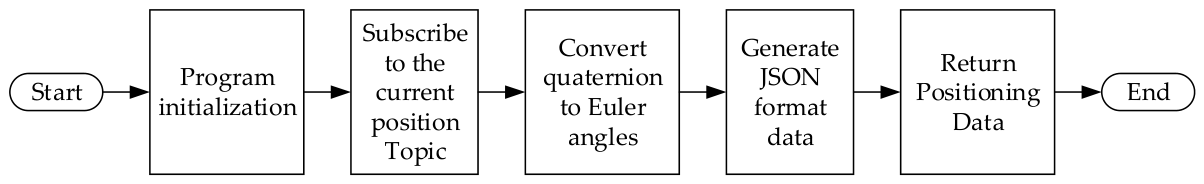
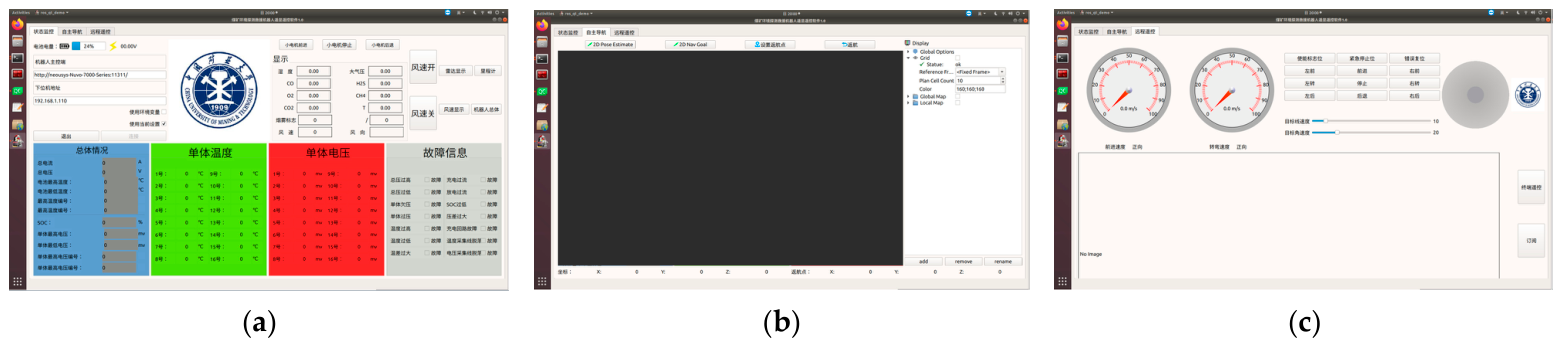
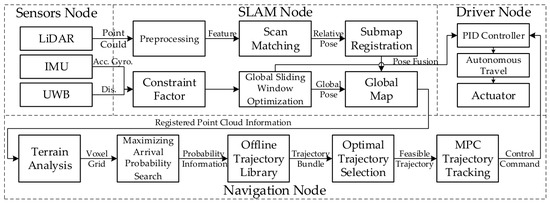
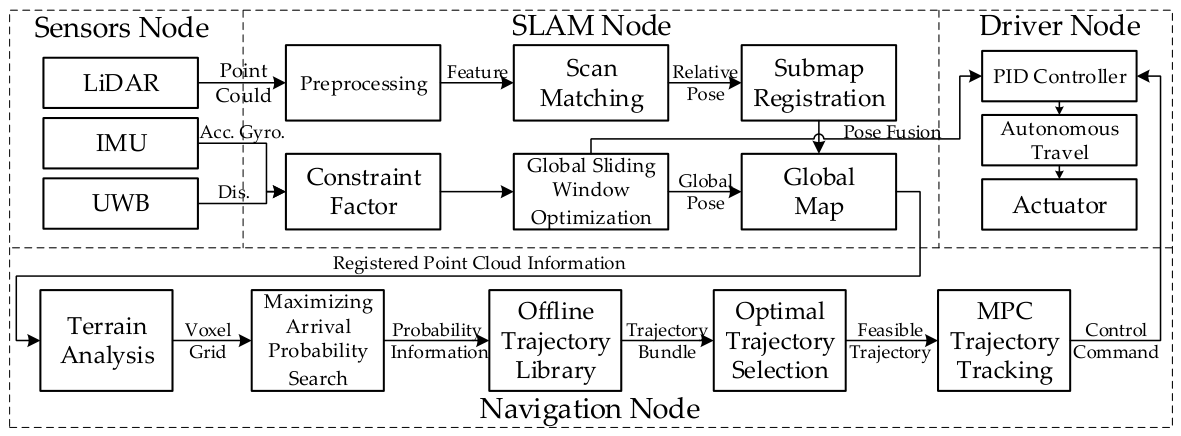
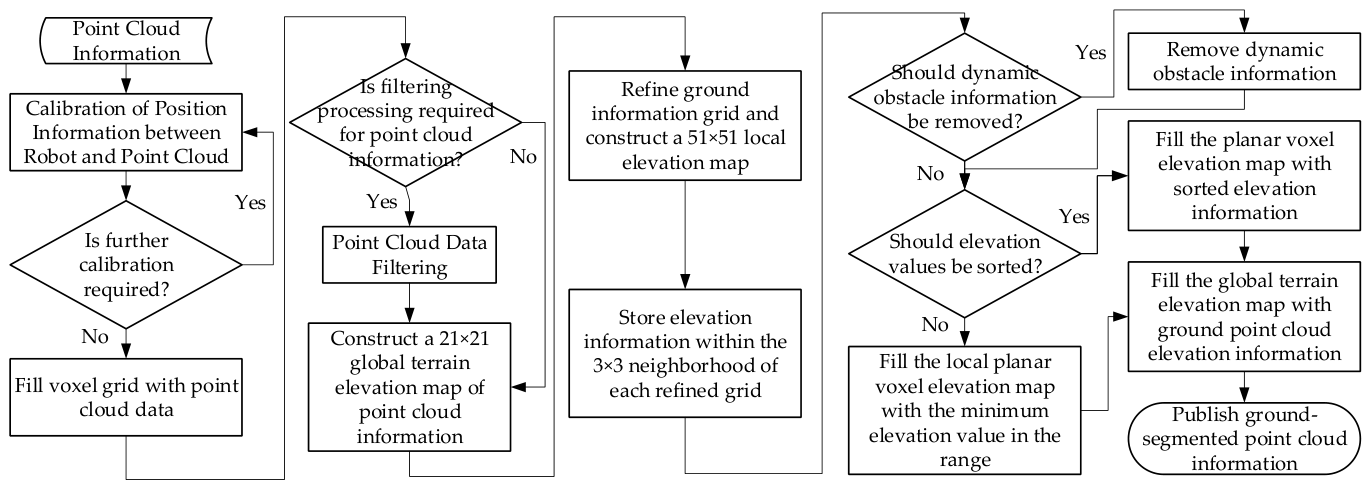
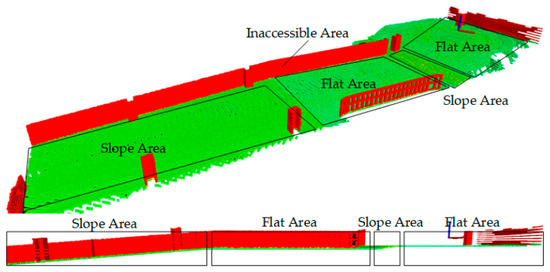
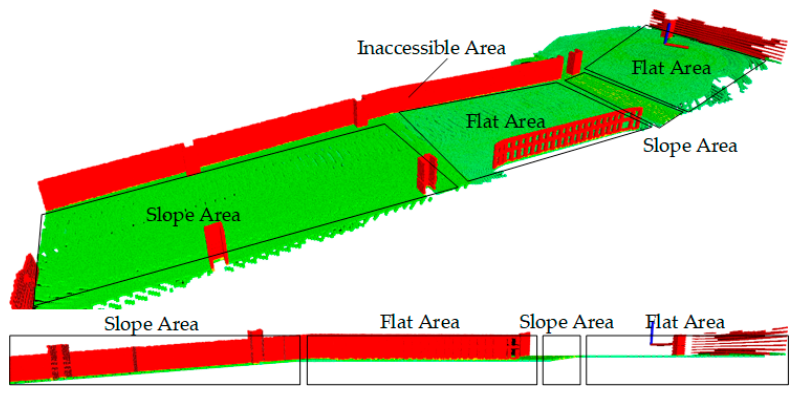
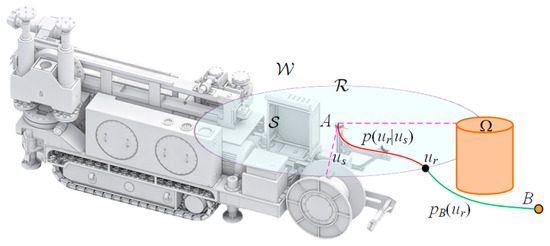
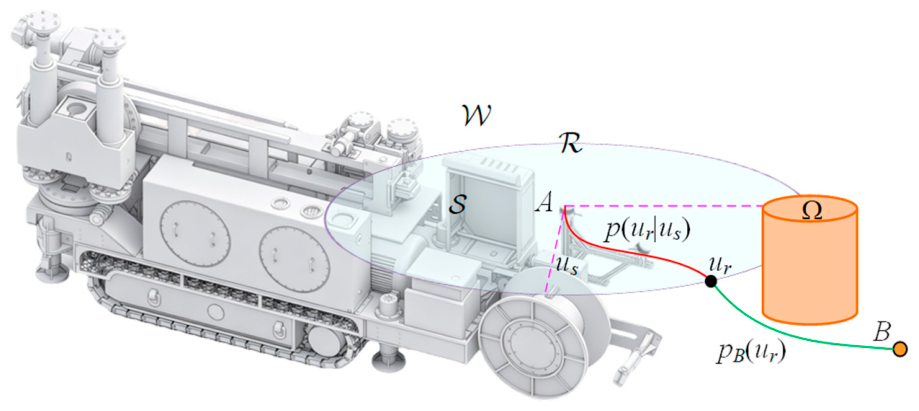
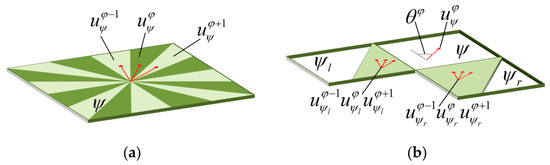
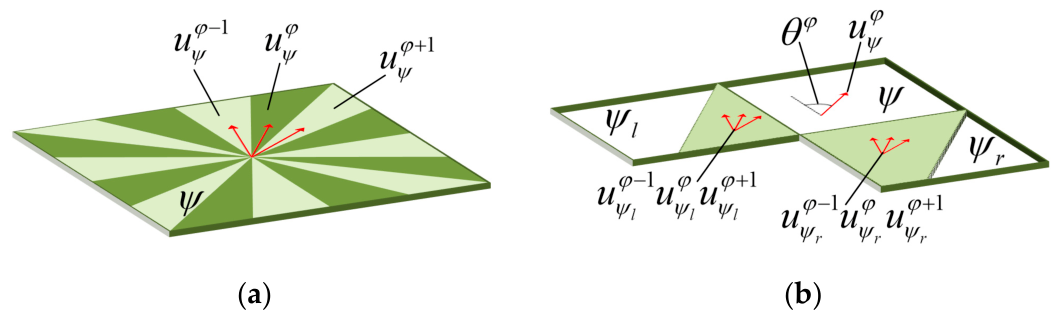
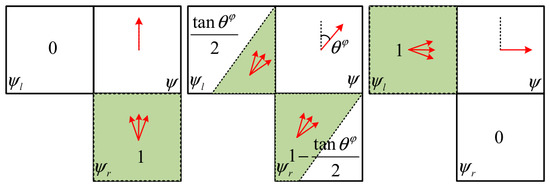
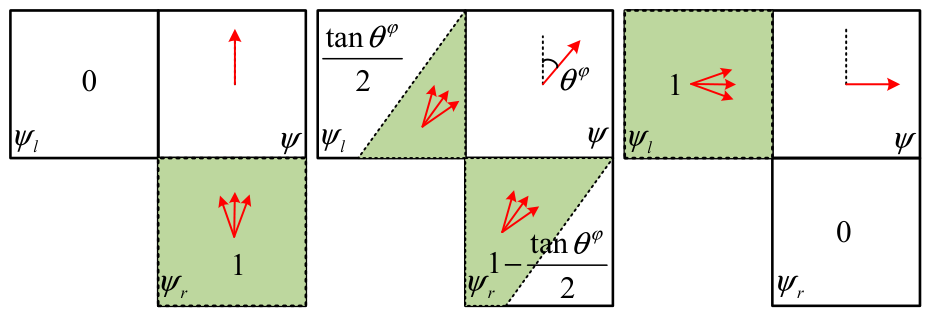
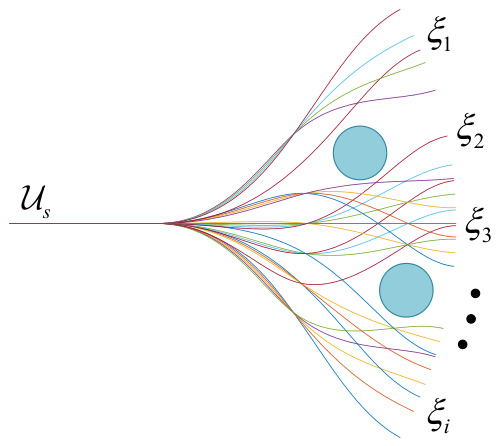
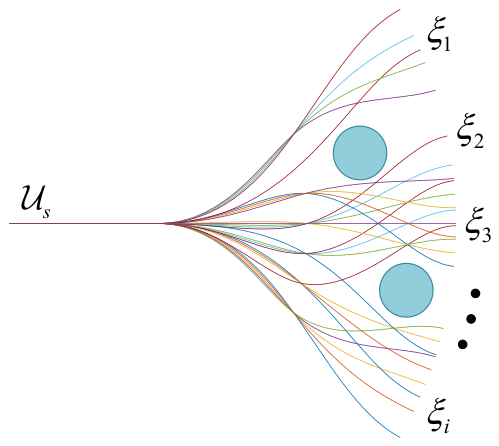
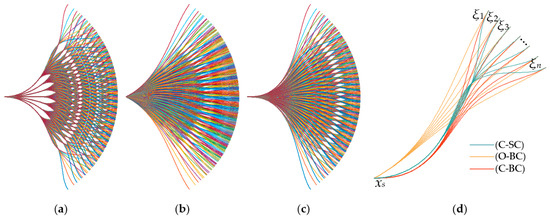
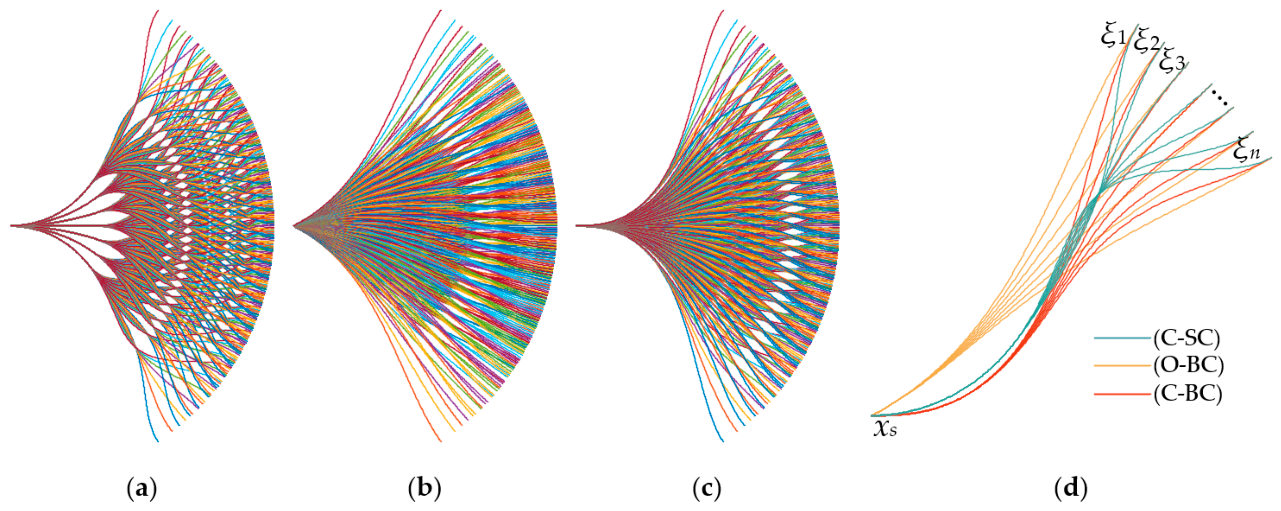
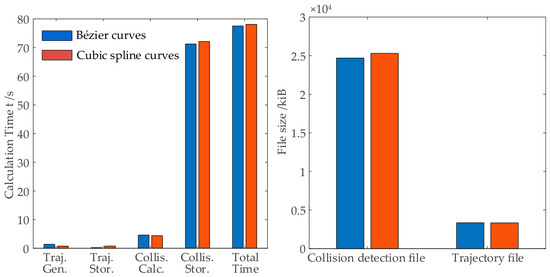
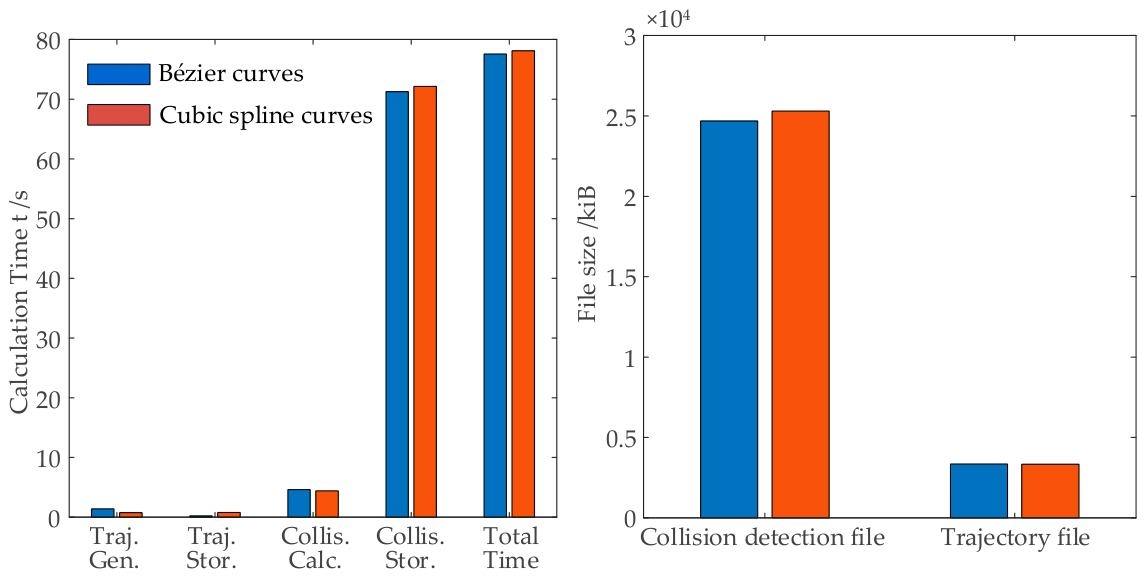
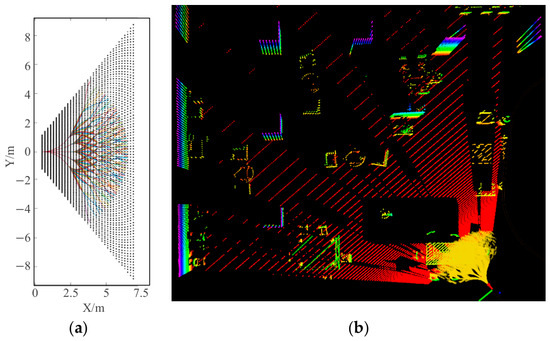
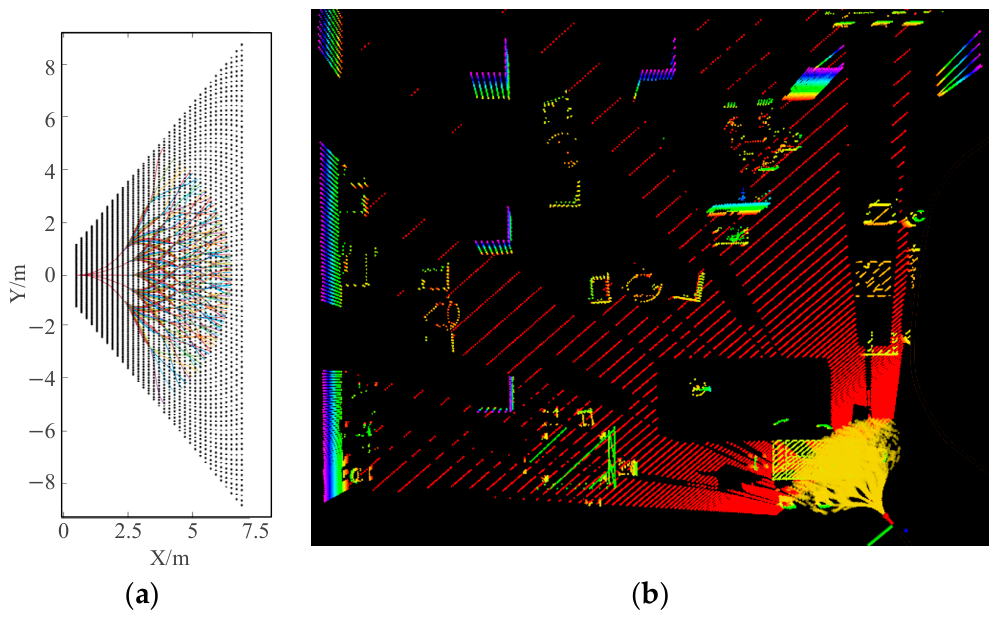
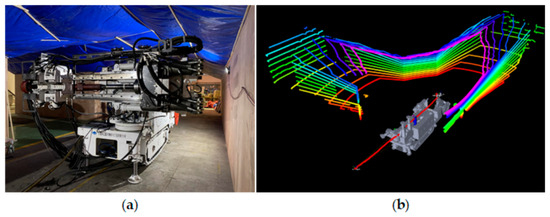
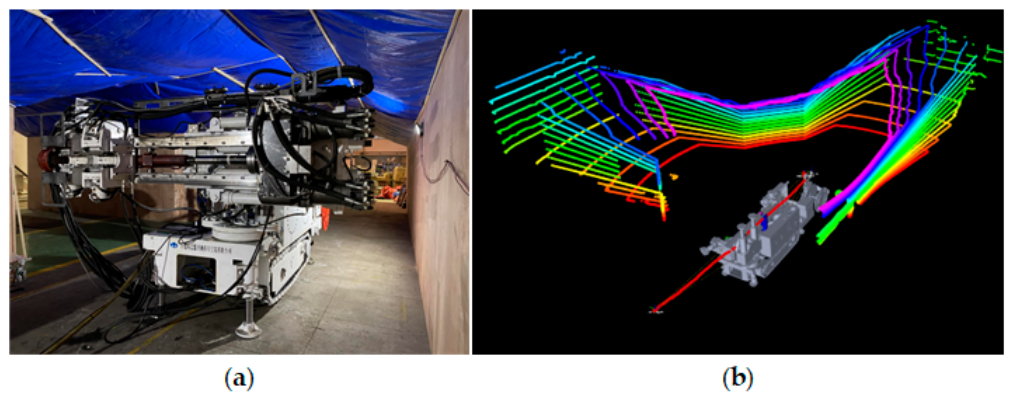
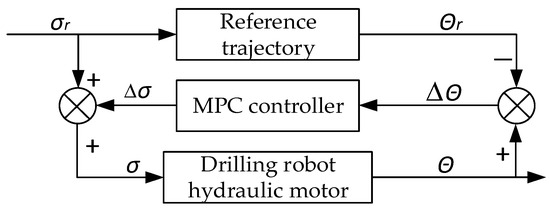
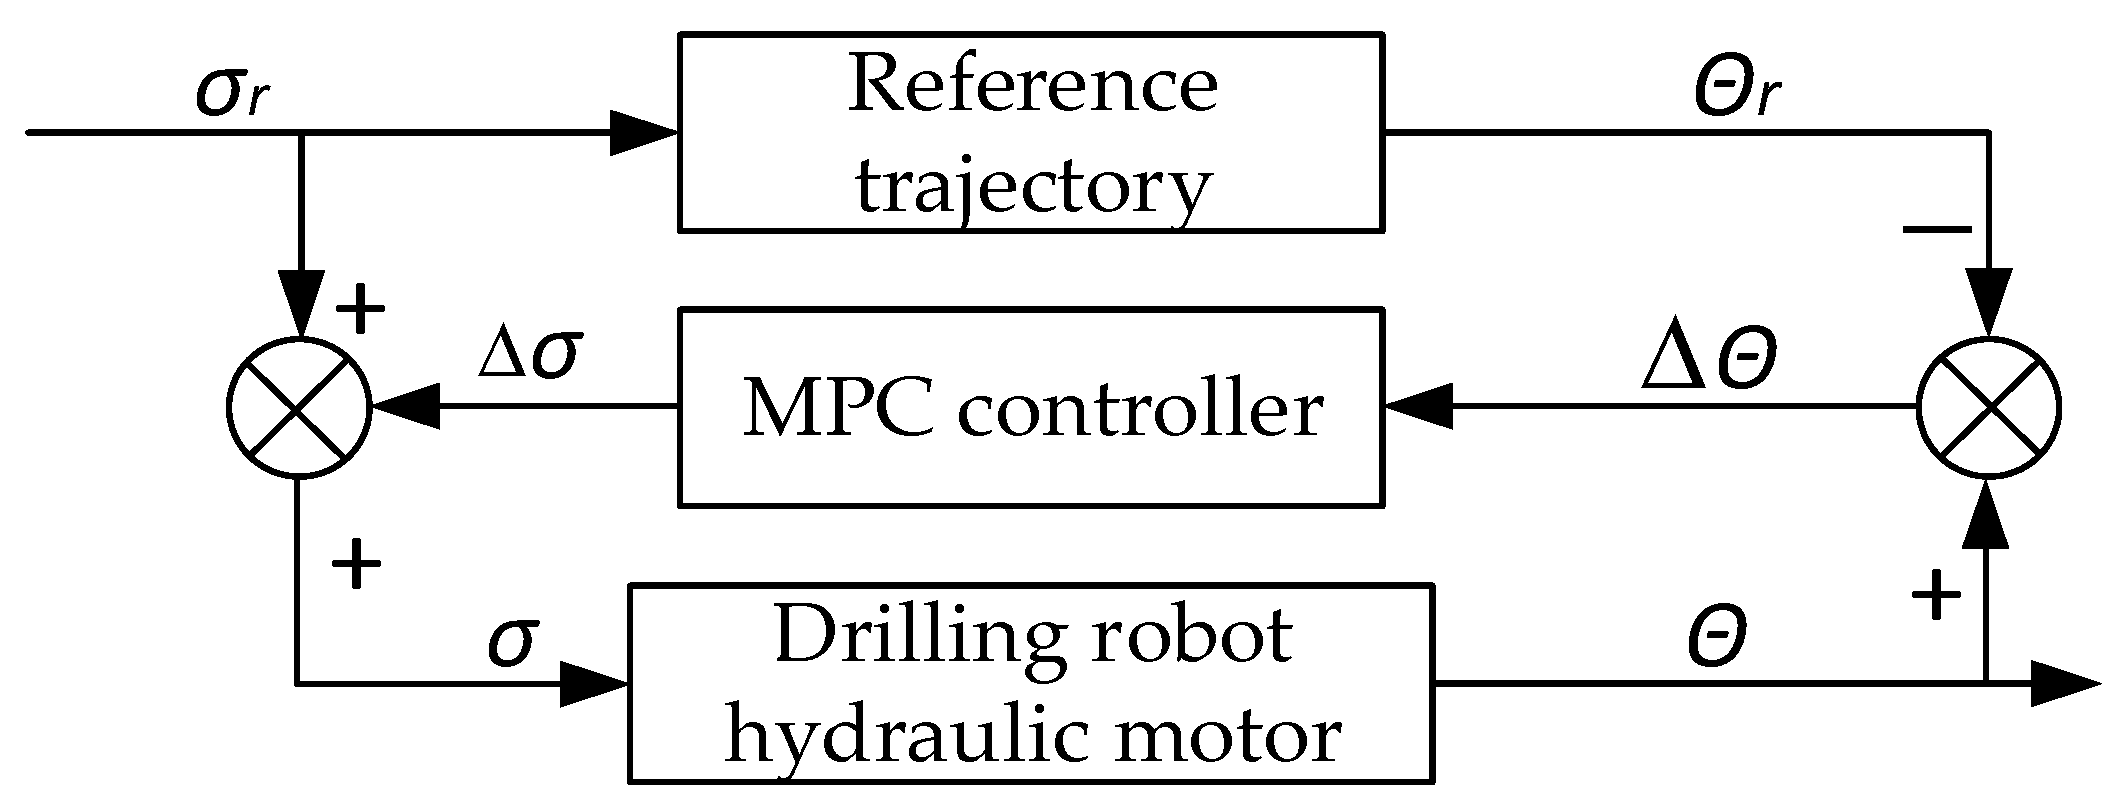
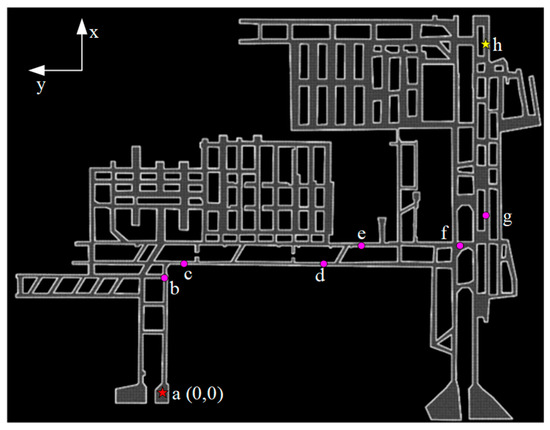
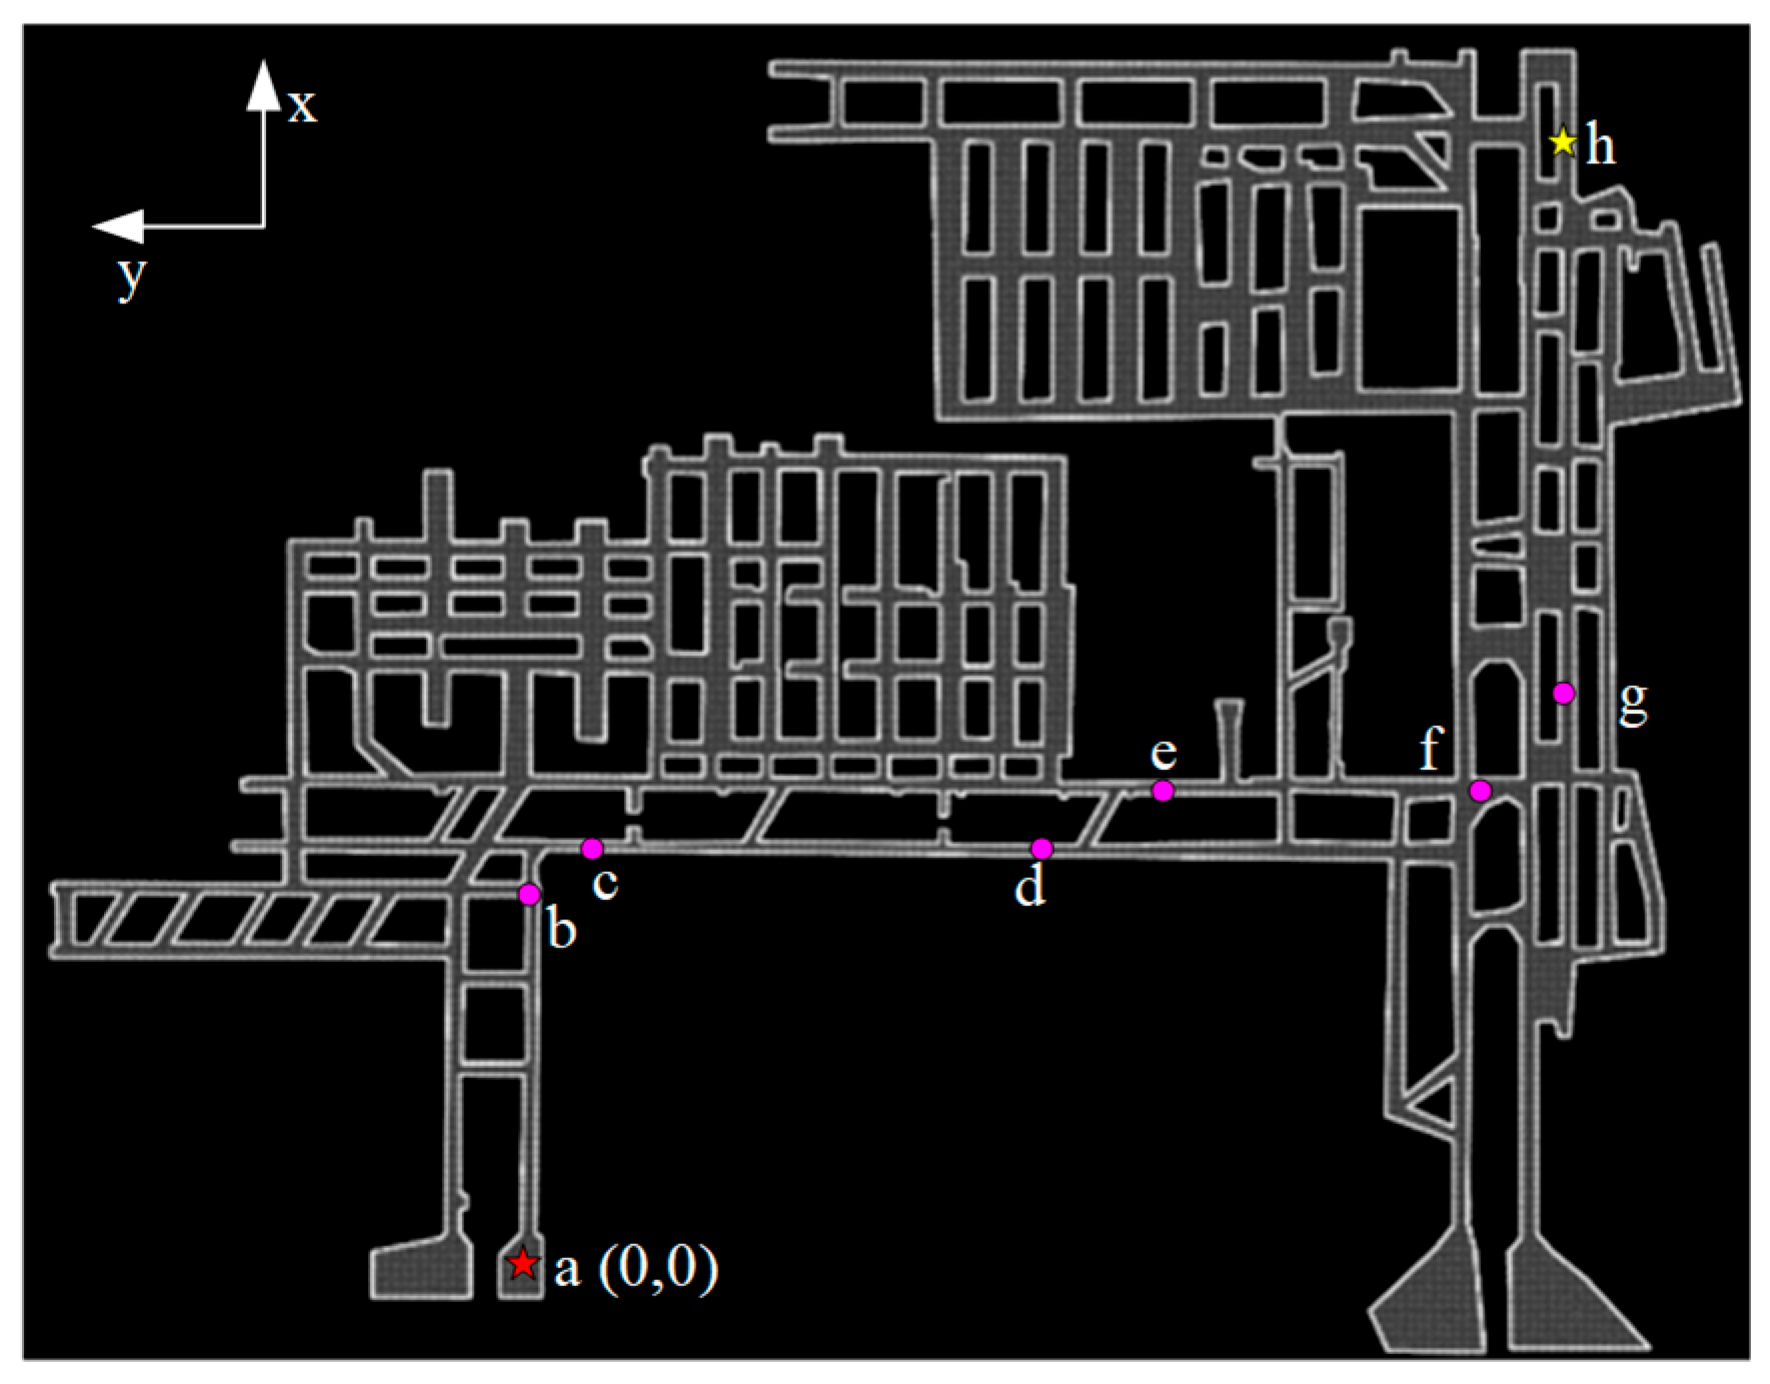
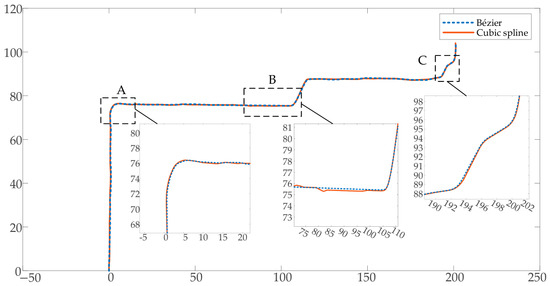
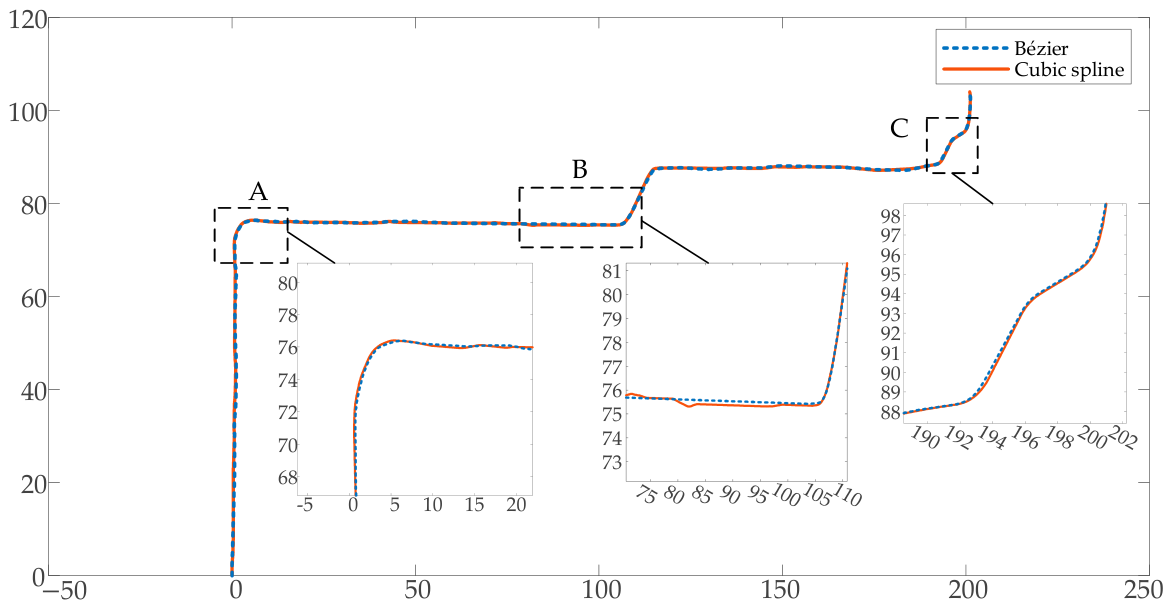
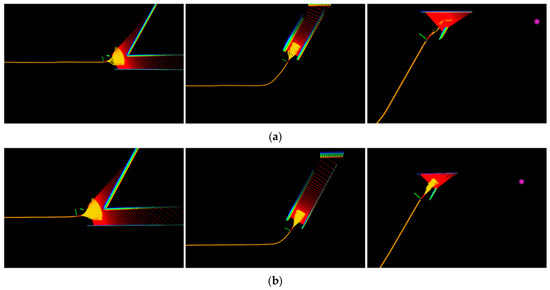
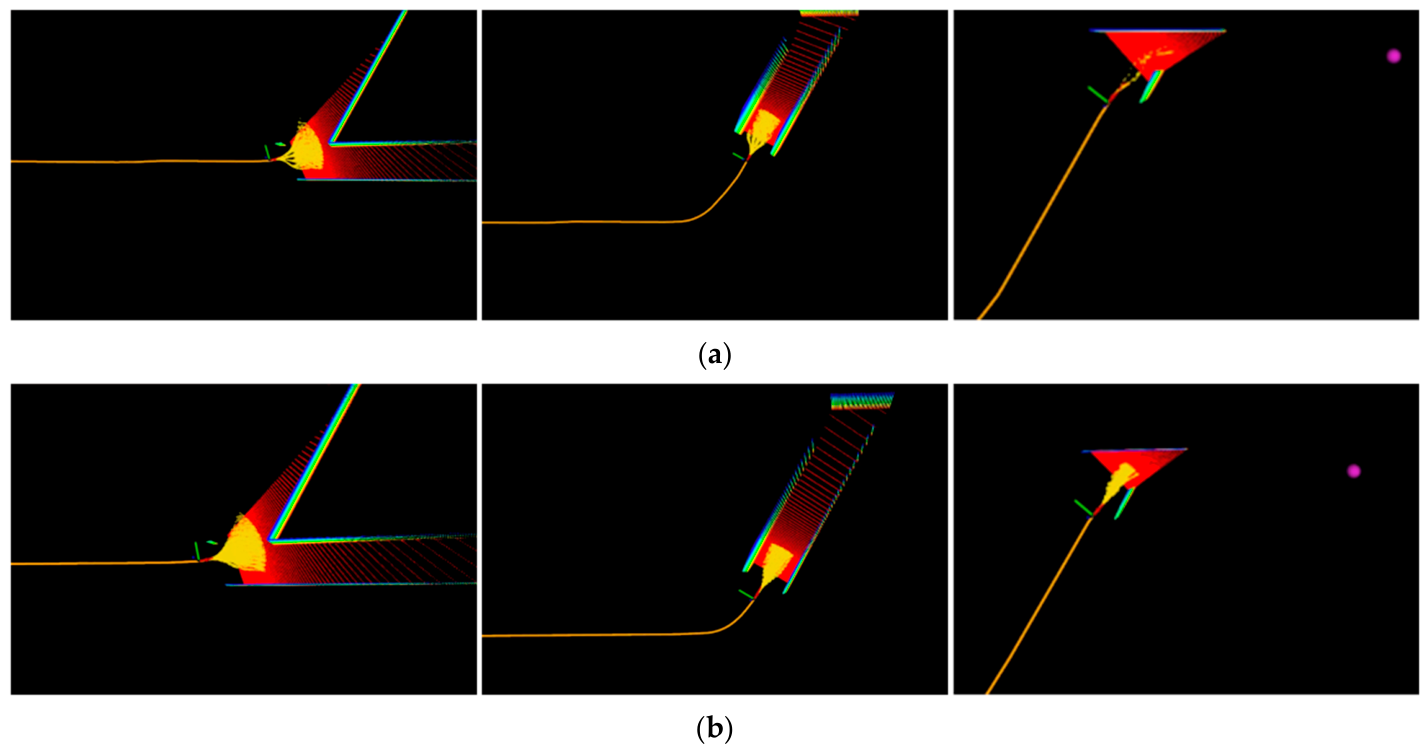
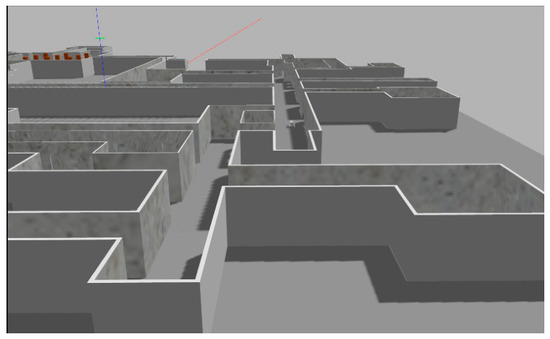
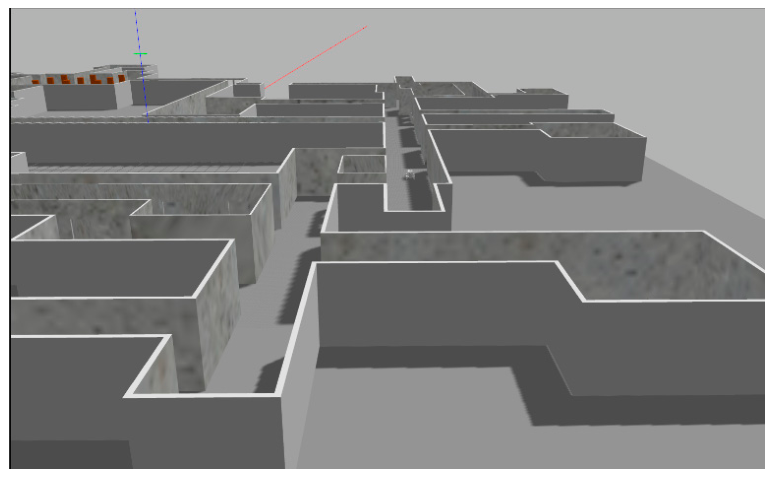
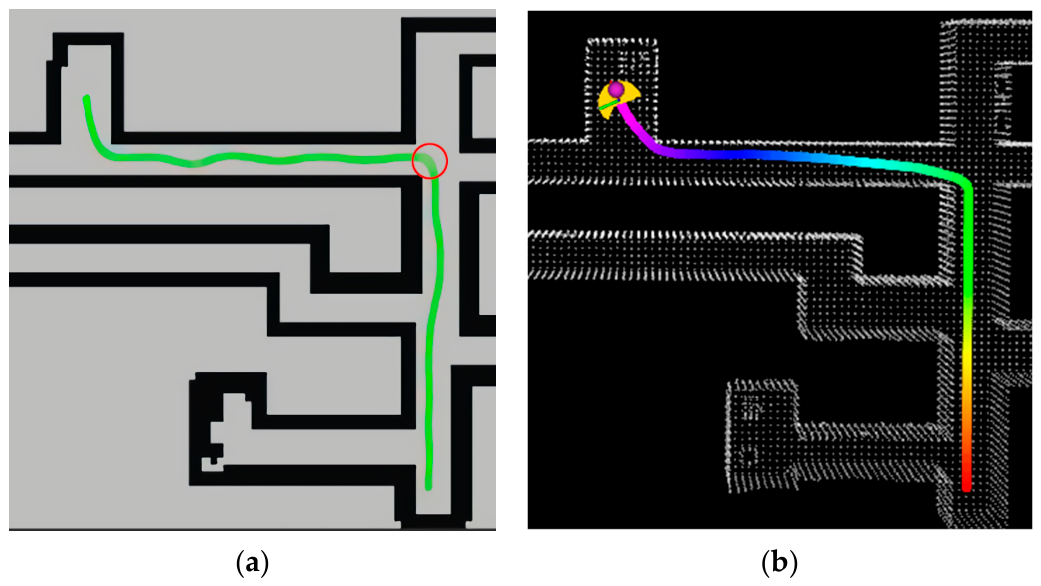
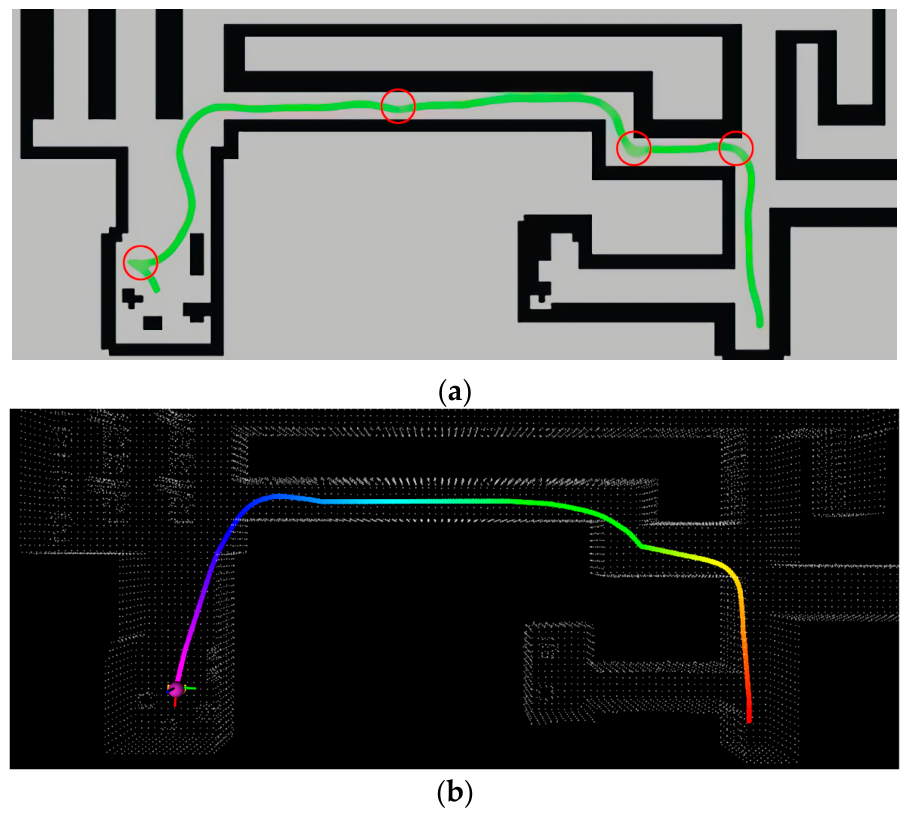
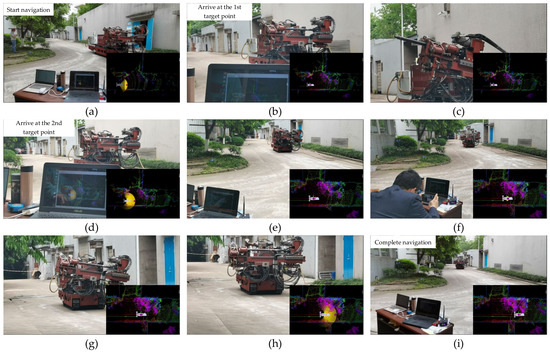
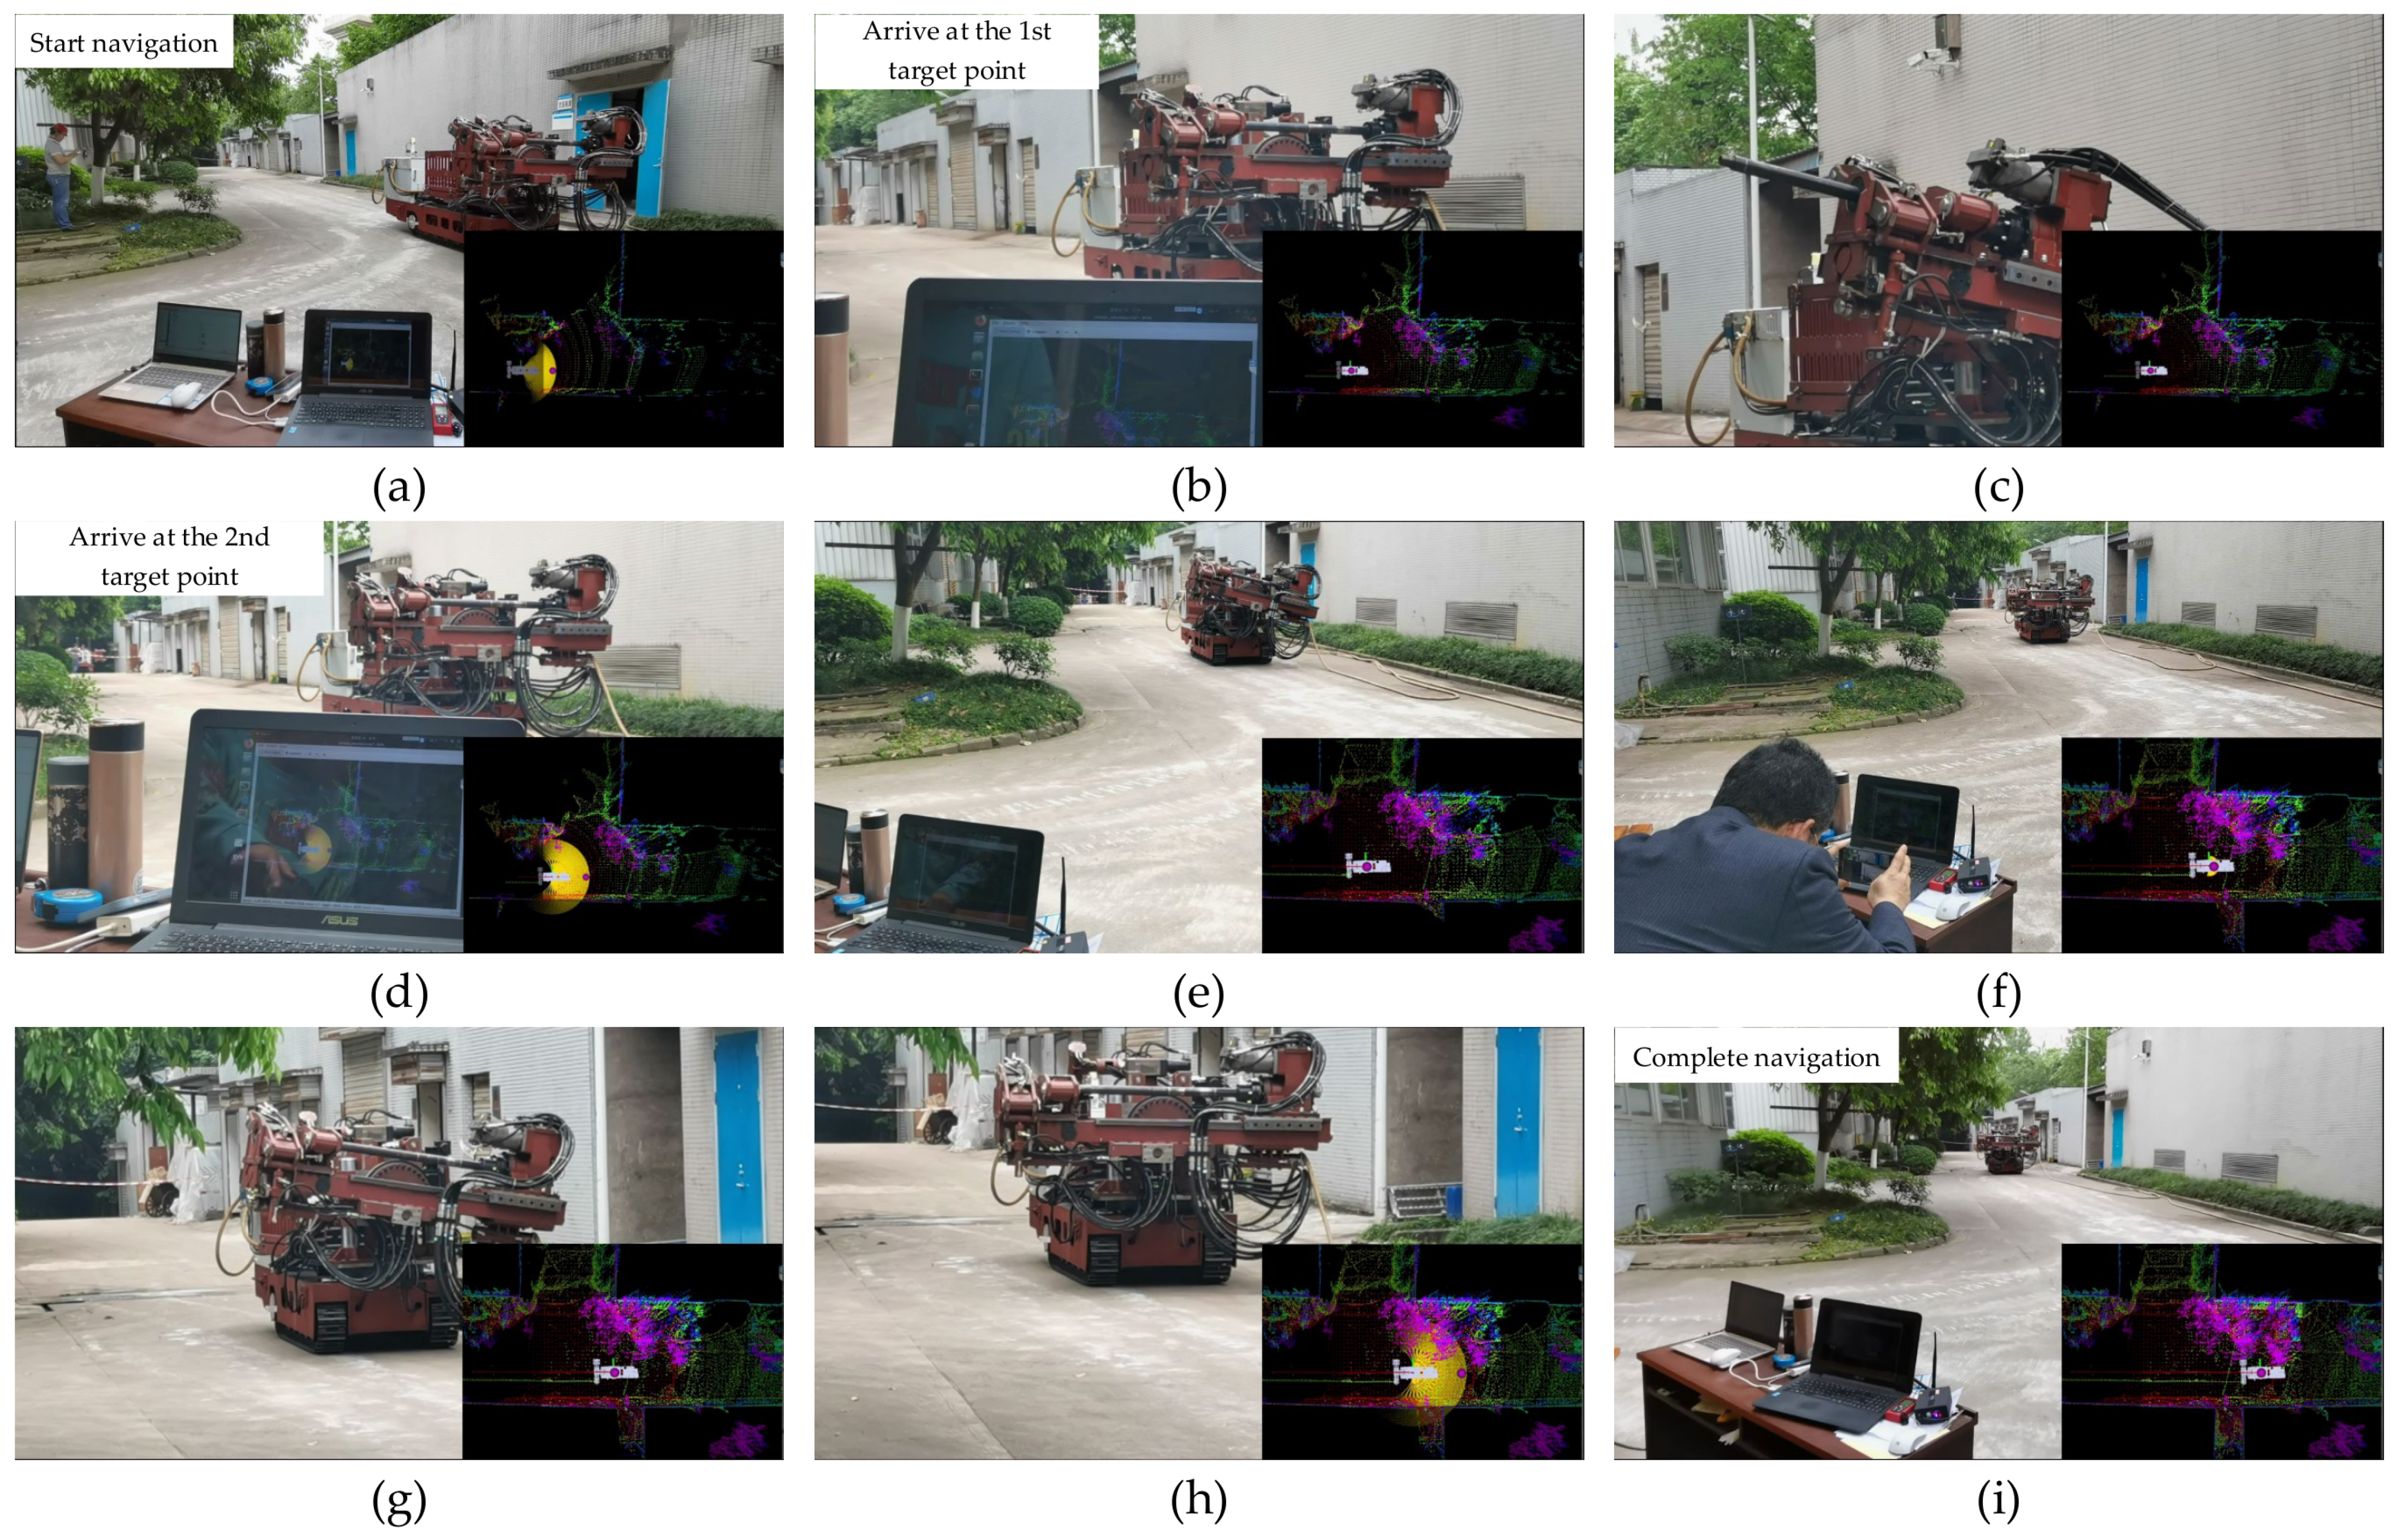
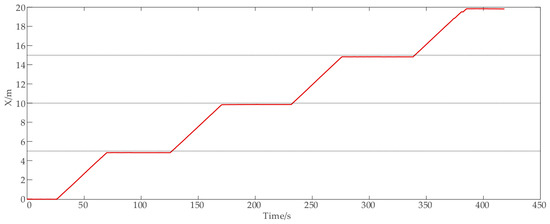
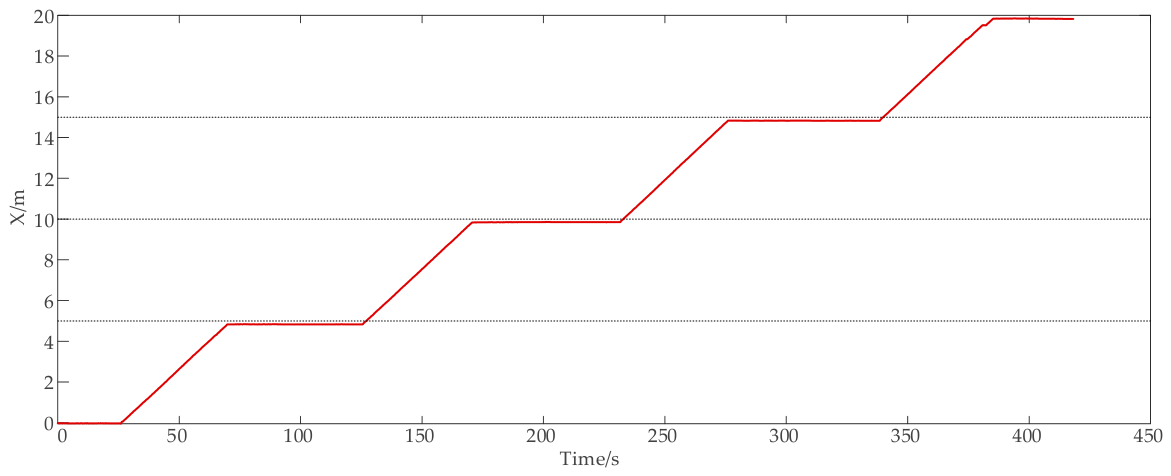
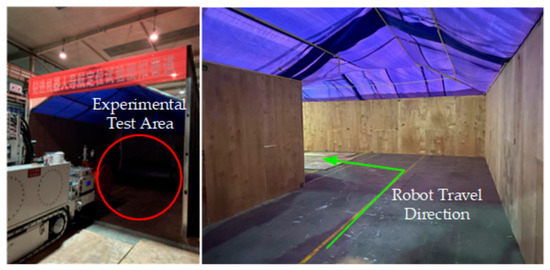
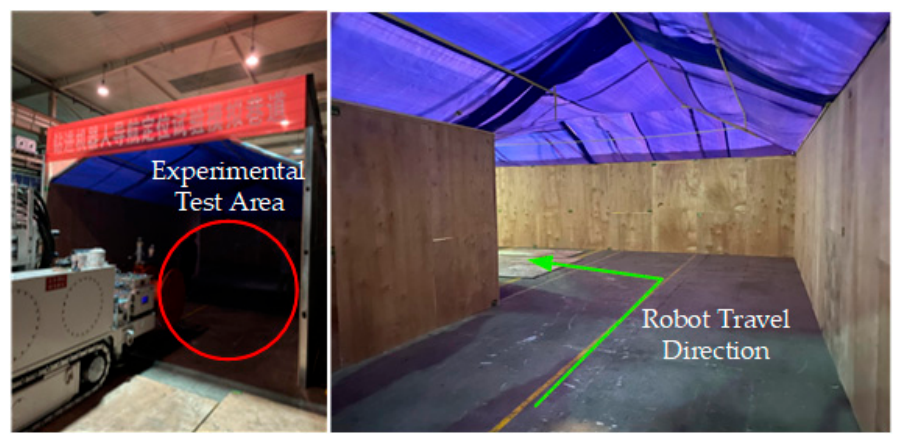
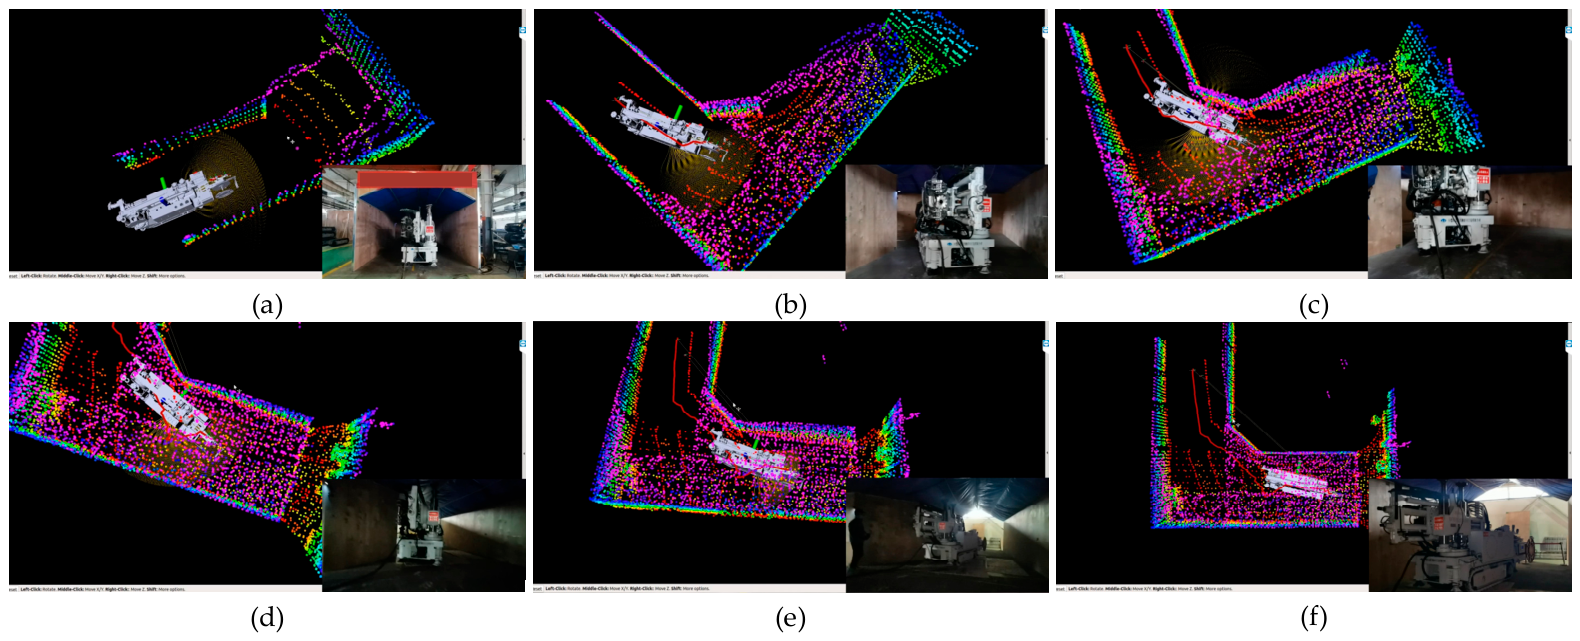
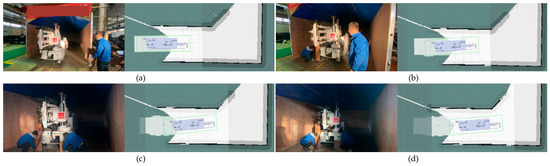
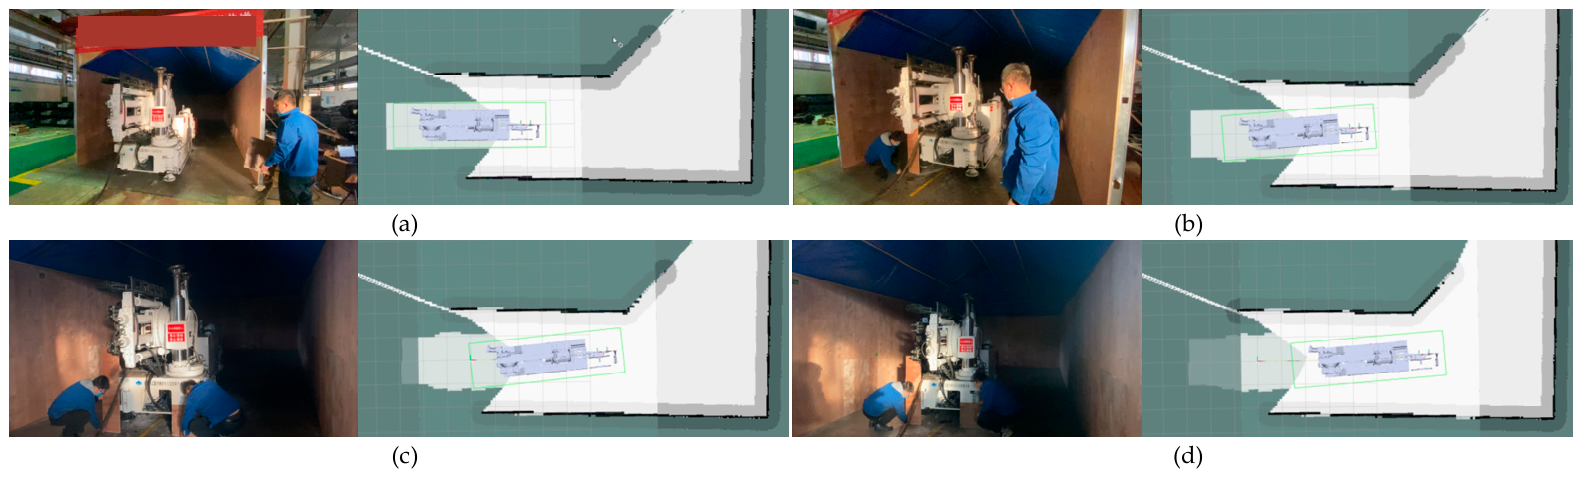
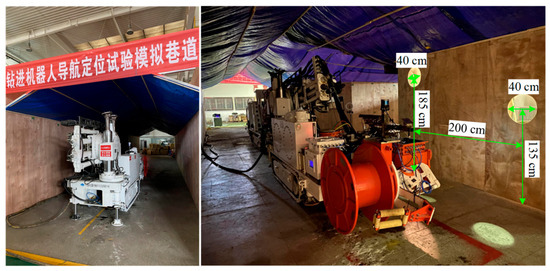
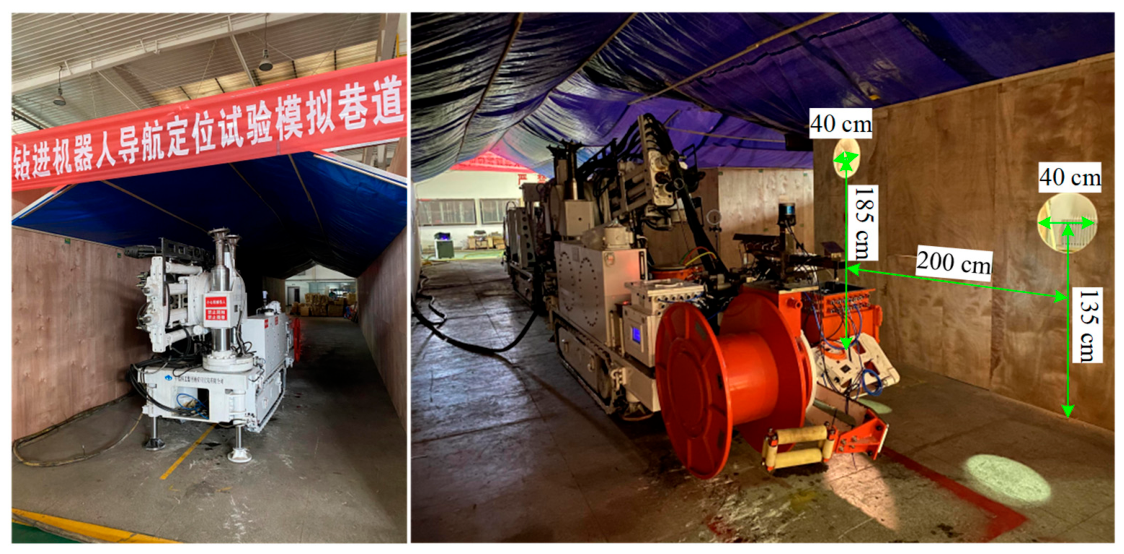
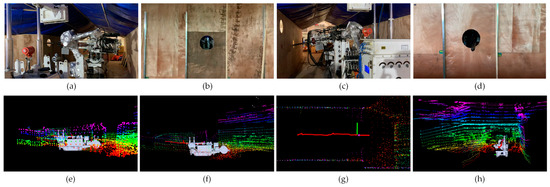
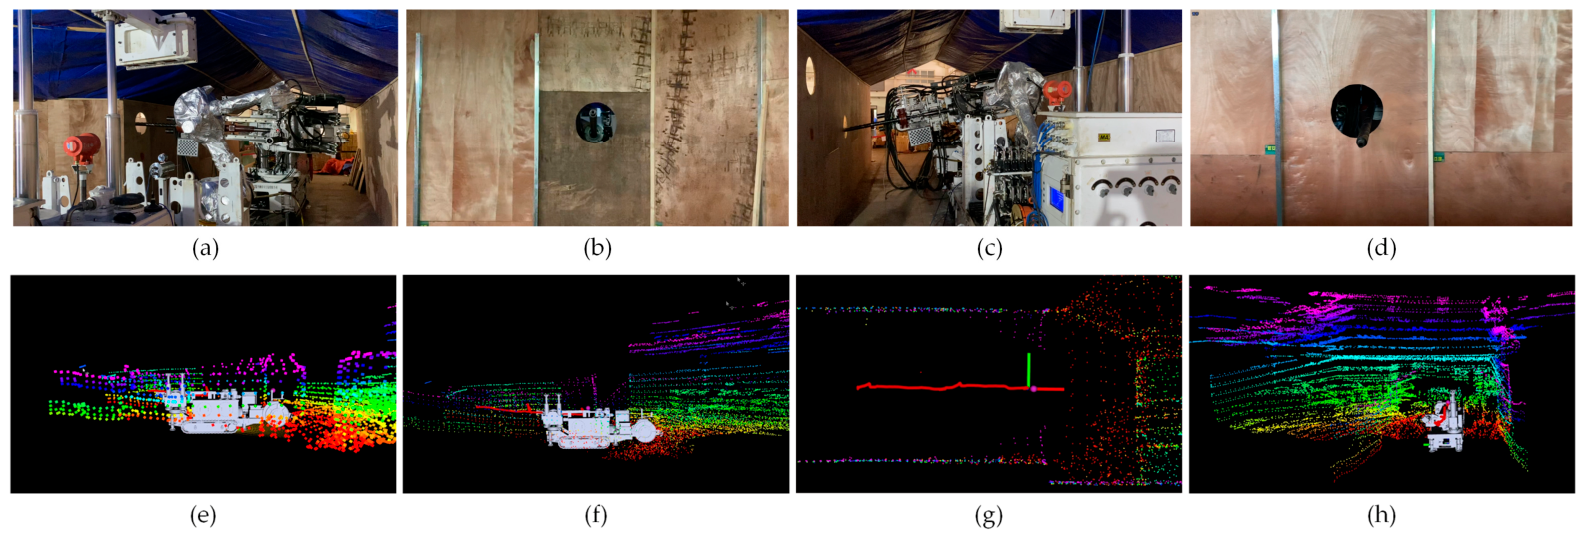
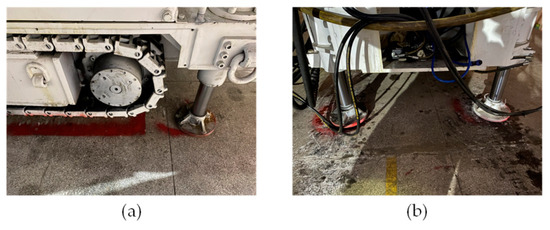
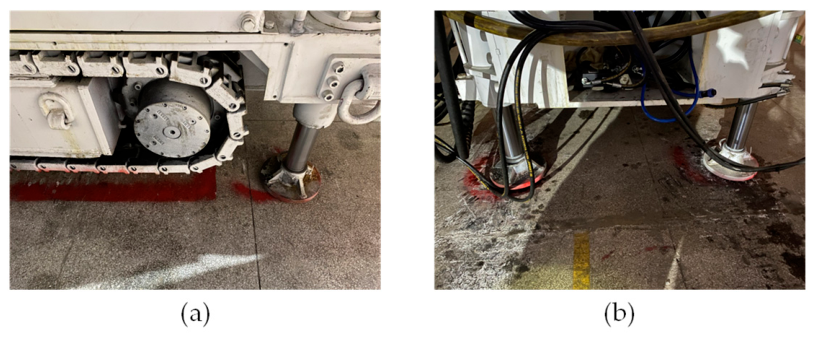
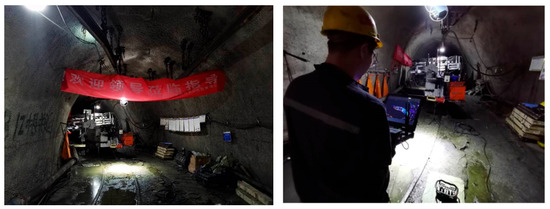
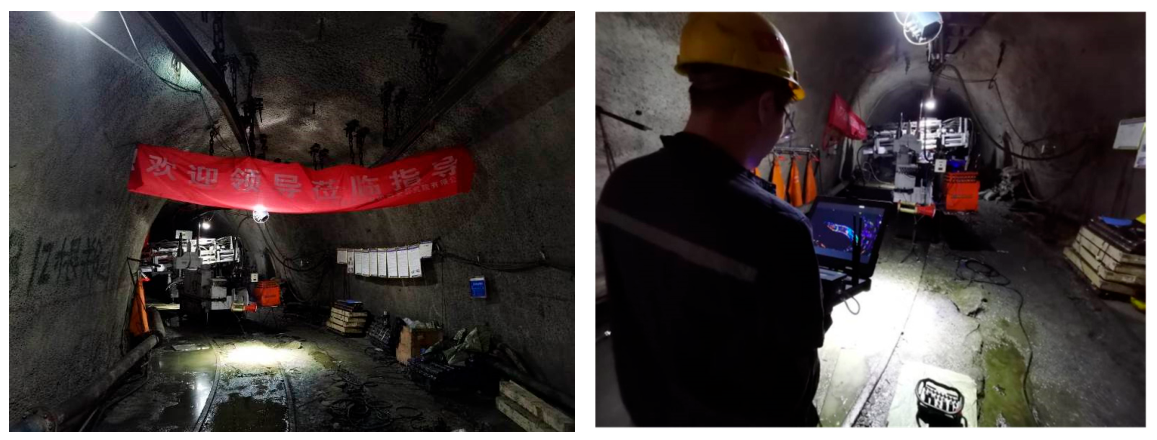
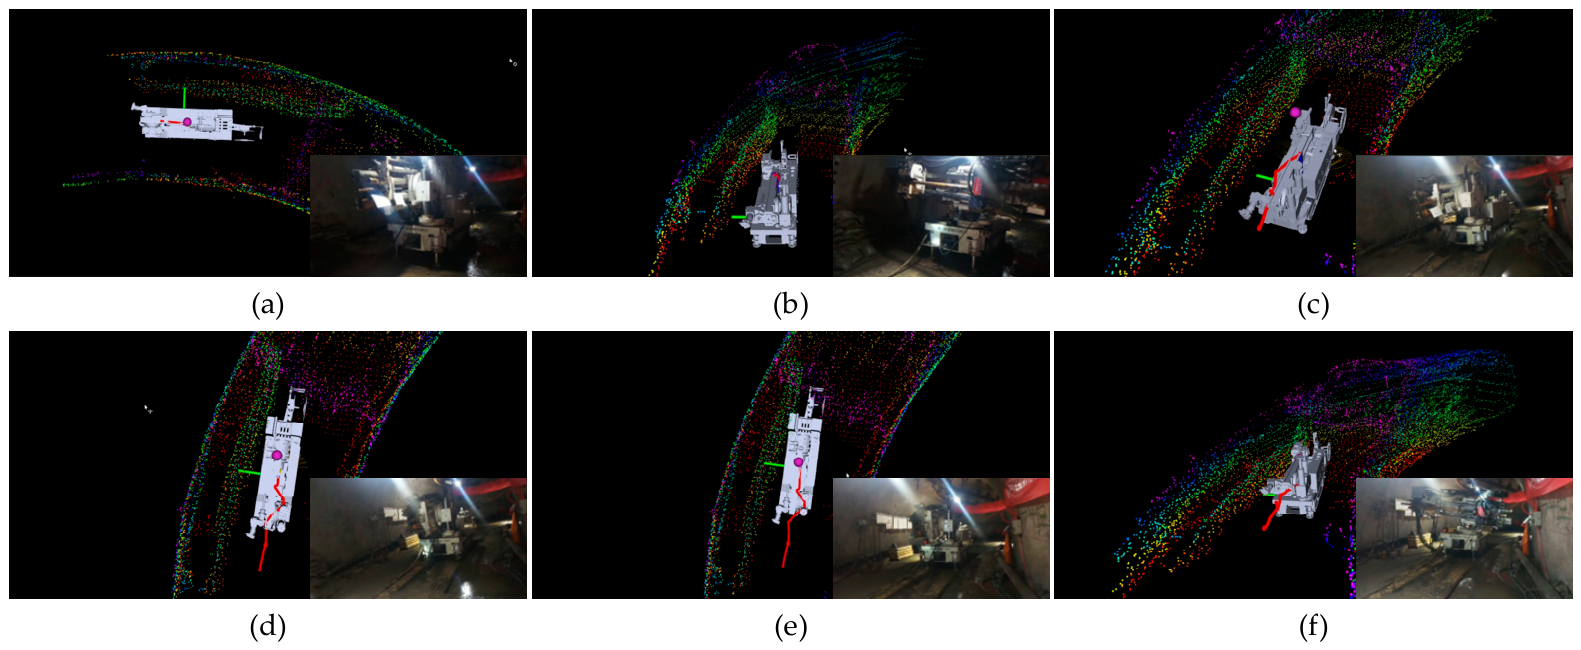

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.