


Abstract
The primary goal of this paper is to present and study an inertial projection algorithm for solving the split best proximity and mixed equilibrium problems. We find a solution of the best proximity problem in such a way that its image under a bounded linear operator is the solution of the mixed equilibrium problem under the setting of real Hilbert spaces. We construct an iterative algorithm for the proposed problem and prove a weak convergence theorem. Moreover, we deduce some consequences from the main convergence result. Finally, a numerical experiment is presented to demonstrate the convergence analysis of our algorithm. The methodology and results presented in this work improve and unify some previously published findings in this field.
Keywords:
iterative algorithm; mixed equilibrium problem; best proximally nonexpansive mapping; weak convergence MSC:
41A29; 47J20; 47J25
1. Introduction
Let for j = 1, 2 be two real Hilbert spaces with the inner product and the induced norm . Let for j=1,2 and be nonempty, closed and convex subsets of and , respectively.
In 1994, Blum and Oettli [1] introduced and studied the following equilibrium problem (EP):
where is a bifunction. We represent the solution set of problem (1) by EP(.
The equilibrium problem is a generalization of many mathematical models such as the variational inequality problem, fixed point problem, certain optimization problem, Nash equilibrium problem, minimization problem and others; (see [1,2,3]).
In 2011, Moudafi [4] introduced and studied the following split equilibrium problem (SEP):
where and are two bifunction and is a bounded linear operator. We represent the solution set of problem (2) and problem (3) with EP() and EP(), respectively. An important generalization of SEP (2) and (3) is the split mixed equilibrium problem (SMEP):
where and be two nonlinear mappings. When we looked separately (4) is the mixed equilibrium problem that Moudafi and Thera [5] introduced and studied in 1999. We represent the solution set of problem (4) and problem (5) by MEP() and MEP(), respectively.
In 2018, Kazmi et al. [6] proposed and studied the following iterative algorithm: For a given , compute iterative sequence generated as follows:
where are two real sequences in (0, 1), , , , are two nonexpansive mappings and . Under some mild conditions, they proved that the sequence induced by (6) converges weakly to an element of the solution set of the mixed equilibrium problem and hierarchical fixed point problem.
On the other hand, if are two nonempty, closed and convex sets with and and are a mapping. The best proximity problem (BPP) is defined as:
We represent the solution set of problem (7) by . The best proximity point problem for nonlinear mappings is an interesting topic in the optimization theory (see [7,8,9]). It is well known that the concept of a best proximity point includes that of a fixed point as a specific case. Some authors have developed some methods for solving the best proximity point problems (see [10,11]) and equilibrium problem (see [1,5,12,13,14,15]).
In 2016, Suantai et al. [16] proposed and studied the following iterative algorithm for solving split equilibrium problem and fixed point problem of non-spreading multivalued mapping in real Hilbert spaces:
where (0, 1], (0, ∞), is a non-spreading multivalued mapping and such that is the spectral radius of where is the adjoint of the bounded linear operator . Under some mild conditions, they proved that the sequence induced by (8) converges weakly to an element of the common solution of split equilibrium problem and fixed point problem.
In 2019, Tiammee and Suantai [17] proposed and studied the following iterative algorithm for solving the split best proximity point and equilibrium problems in Hilbert spaces:
where (0,1], (0, ∞), and Under some mild conditions, they proved that the sequence induced by (9) converges weakly to an element of the solution set .
In this paper, we introduce and study a new split problem, which is called a split best proximity problem and mixed equilibrium problem (SBPMEP). Let be two nonempty, closed and convex subsets of with and Let be a closed convex subset of and be a bounded linear operator. Let be a mapping, be a bifunction and be a nonlinear mapping. Then SBPMEP is defined as:
We represent the solution set of SBPMEP by When we looked separately (10) is a classical best proximity point problem and (11) is a classical mixed equilibrium problem (see [18,19,20]).
In particular, the term , also known as the inertial extrapolation term was introduced as a useful tool for speeding up the convergence rate of iterative methods and many authors have investigated and improved the inertial type algorithm in various forms (see [21,22]).
Motivated and inspired by the work of Suantai et al. [16] and Tiammee and Suantai [17] and ongoing work in this direction, we propose and analyze an iterative algorithm for solving the SBPMEP (10) and (11) and establish a weak convergence theorem. The results obtained in this paper can be considered as the common solution of the best proximity point problem and mixed equilibrium problem and is a generalization of the recently published work by Tiammee and Suantai [17]. The iterative algorithm and results discussed in this paper are novel and can be viewed as a generalization and refinement of previously published work in this field.
The paper is organized as follows. In Section 1, we propose and formulate our problem and give a brief introduction of the work undertaken in this direction. In Section 2, we recall some concepts and results which are needed in proving the result presented in this paper. In Section 3, we prove a weak convergence theorem for an SBPMEP (10) and (11). In Section 4, we deduce some consequences from our main convergence theorem. In Section 5, we give a numerical example to justify our main convergence result while the conclusion is given in the last section.
2. Preliminaries
In this section, we need to review some basic definitions and lemmas that are required to prove our main convergence result. We denote the symbol ⇀ for weak convergence.
A mapping is said to be
- nonexpansive if
- -inverse strongly monotone if there exists such that
- quasi-nonexpansive if Fix() andwhere Fix(. Observe that nonexpansive mappings are quasi-nonexpansive.
Let and be two nonempty, closed and convex subsets of . We define the following sets by and
and
A metric projection of is defined by
The projection operator has the well known properties which are described in the following lemma.
Lemma 1
([23]). Let be a nonempty, closed and convex subset of Hilbert space . Then ∀ and ,
- (a)
- (b)
- (c)
- ;
- (d)
- .
A Hilbert space is said to satisfy Opial’s condition if, for any sequence in such that , we have
Lemma 2
([11]). Let and be two nonempty subsets of a uniformly convex Banach space such that is closed and convex. Assume that is a mapping such that . Then Fix=.
Definition 1
([11]). Let and be two nonempty subsets of a real Hilbert space and a subset of . A mapping is called -nonexpansive if
If , then is called a best proximally nonexpansive mapping.
Definition 2
([24]). Let and be two nonempty and closed subsets of a metric space . Then, and are said to satisfy the P-property if for and , the following implication holds:
Notice that the P-property holds for any pair () of nonempty, closed and convex subsets of .
Lemma 3
([10]). Let and be two nonempty subsets of a uniformly convex Banach space such that is closed and convex. Suppose that is mapping such that Then satisfies the proximal property iff is demiclosed at zero.
Lemma 4
([1]). Let be a nonempty, closed and convex subset of and be a bifunction satisfying the following conditions:
- (B1)
- (B2)
- ψ is monotone, i.e,
- (B3)
- For each
- (B4)
- For each , is convex and lower semicontinuous.
Lemma 5
([14]). Let be a nonempty, closed and convex subset of and let be a bifunction satisfying . Define a mapping is defined by
Then the following results holds:
- (a)
- is single-valued;
- (b)
- is firmly-nonexpansive, i.e,
- (c)
- Fix
- (d)
- Fix is closed and convex.
Lemma 6
([25]). For all , we have
For any , we have
Lemma 7
([26]). Let and be non-negative sequences satisfying
Then is a convergent sequence.
3. Main Result
In this section, we prove our main convergence result based on the proposed iterative algorithm for solving SBPMEP (10) and (11).
Theorem 1.
Let for j=1,2 and be nonempty, closed and convex subsets of and , respectively. Let be a bounded linear operator with adjoint operator . Let be best proximally nonexpansive mapping such that with . Let be a ζ-inverse strongly monotone mapping and let be a bifunction satisfying ( with . Suppose that satisfies the proximal property. Let be a sequence generated by
where (0,1], (0,∞), for some and is a constant. Suppose that . Moreover, let the following conditions be satisfied:
- (i)
- (ii)
- (iii)
Then, the sequence converges weakly to
Proof.
Let . Since and using P-property, we have
Since , . Now
Since is a best proximally nonexpansive mapping, using (13), we have
Moreover, since , So and , we have
By Lemma 5 and , we have
which implies that
Now, using (17) and Lemma 6 (b), we calculate
From (18), we obtain
Therefore, from Lemma 7, Again by (20), we have Consequently, is bounded. Hence, the sequences and are also bounded.
By (16), we have
As is bounded, has a weakly convergence subsequence . Let us consider that for some . Then, and by (22) and is a bounded linear operator.
Since (19) implies that
Now, we prove that , that is and . Since satisfies proximal property, by Lemma 3, we have is demiclosed at zero. It follows from (21) that , i.e, .
Now, we prove that . Since is a bounded linear operator, we have . Setting , we obtain and Therefore, from Lemma 5, we have +
Since is upper semicontinuous in the first argument, taking limsup to the above inequality as and using (iii), we obtain
this implies that . This shows that □
4. Consequences
In this section, we deduce some special cases from our main convergence theorem.
In Theorem 1, if we take and , we have the following result for solving the split best proximity problem and equilibrium problem which was initially studied and analyzed by Tiammee and Suantai [17].
Corollary 1.
Let for j = 1,2 be two real Hilbert spaces and let for j=1,2 and be nonempty, closed and convex subsets of and , respectively. Let be a bounded linear operator with adjoint operator . Let be best proximally nonexpansive mapping such that with . Let : be a bifunction satisfying ( with . Assume that satisfies the proximal property. Let be a sequence generated by
where (0,1], (0,∞) and is a constant. Suppose that . Moreover, let the following conditions be satisfied:
- (i)
- (ii)
Then, the sequence converges weakly to
In Theorem 1, if , and , the identity mapping on , then we have the following result to approximate a common solution of the best proximity problem (7) and mixed equilibrium problem (5).
Corollary 2.
Let be a real Hilbert space and let for j = 1, 2 be two nonempty, closed and convex subsets of . Let be best proximally nonexpansive mapping such that with . Let be a ζ-inverse strongly monotone mapping and let : be a bifunction satisfying ( with . Assume that satisfies the proximal property. Let be a sequence generated by
where (0,1], (0,∞), for some and . Suppose that . Moreover, let the following conditions be satisfied:
- (i)
- (ii)
- (iii)
Then, the sequence converges weakly to
In Theorem 1, if , and , the identity mapping on and , then we have the following result for solving best proximity problem (7) and equilibrium problem (3).
Corollary 3.
Let be a real Hilbert space and let for j=1,2 be two nonempty, closed and convex subsets of . Let be best proximally nonexpansive mapping such that with . Let : be a bifunction satisfying ( with . Assume that satisfies the proximal property. Let be a sequence generated by
where (0,1], (0,∞), for some and . Suppose that . Moreover, let the following conditions be satisfied:
- (i)
- (ii)
- (iii)
Then, the sequence converges weakly to
5. Numerical Experiment
In this section, we present a numerical experiment to justify our main convergence result.
Example 1.
Let the set of real numbers, with the inner product defined by , and induced usual norm and Let be defined as and defined by . Let the mapping be defined by and let the mapping be defined by For , , we compute that
It is easy to check that ψ satisfies and upper semicontinuous. is a bounded linear operator on with adjoint operator and and hence, . Therefore, we choose Further, is -inverse strongly monotone mapping and let us choose It is easy to prove that MEP and is a best proximally nonexpansive mapping such that with Therefore,
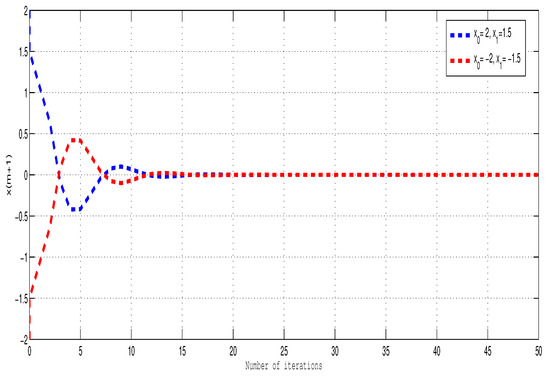
From Table 1 and Figure 1, it can be very well visualized that the sequence of iteration converges weakly to 0.
Table 1.
Numerical experiment for two distinct initial values and .
Figure 1.
Convergence of sequence .
6. Conclusions
In this paper, we suggest and analyze an inertial projection algorithm for solving the split best proximity and mixed equilibrium problems. We approximate a solution of the best proximity problem in such a way that its image under a bounded linear operator is the solution of the mixed equilibrium problem under the setting of real Hilbert spaces. We construct an iterative algorithm for the proposed problem and prove a weak convergence theorem. Further, we deduce some special cases from our main convergence result. Finally, a numerical experiment has been presented to justify the convergence analysis of the proposed iterative algorithm.
Author Contributions
All the authors contributed equally and significantly in writing this article. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Not applicable.
Acknowledgments
All the authors are grateful to the anonymous referees for their excellent suggestions, which greatly improved the presentation of the paper.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Blum, E.; Oettli, W. From optimization and variational inequalities to equilibrium problems. Math. Stud. 1994, 63, 123–145. [Google Scholar]
- Jolaoso, L.; Alakoya, T.; Taiwo, A.; Mewomo, O. Inertial extragradient method via viscosity approximation approach for solving equilibrium problem in Hilbert space. Optimization 2021, 70, 387–412. [Google Scholar] [CrossRef] [Scilit]
- Suantai, S.; Cholamjiak, P. Algorithms for solving generalized equilibrium problems and fixed points of nonexpansive semigroups in Hilbert spaces. Optimization 2014, 63, 799–815. [Google Scholar] [CrossRef] [Scilit]
- Moudafi, A. Split monotone variational inclusions. J. Optim. Theory Appl. 2011, 150, 275–283. [Google Scholar] [CrossRef] [Scilit]
- Moudafi, A.; Théra, M. Proximal and dynamical approaches to equilibrium problems. In Ill-Posed Variational Problems and Regularization Techniques; Springer: Berlin/Heidelberg, Germany, 1999; pp. 187–201. [Google Scholar]
- Kazmi, K.; Ali, R.; Furkan, M. Krasnoselski-Mann type iterative method for hierarchical fixed point problem and split mixed equilibrium problem. Numer. Algorithms 2018, 77, 289–308. [Google Scholar] [CrossRef] [Scilit]
- Basha, S.S. Best proximity points: Optimal solutions. J. Optim. Theory Appl. 2011, 151, 210–216. [Google Scholar]
- Gabeleh, M. Best proximity point theorems via proximal non-self mappings. J. Optim. Theory Appl. 2015, 164, 565–576. [Google Scholar] [CrossRef] [Scilit]
- Sadiq Basha, S. Best proximity points: Global optimal approximate solutions. J. Glob. Optim. 2011, 49, 15–21. [Google Scholar] [CrossRef] [Scilit]
- Bunlue, N.; Suantai, S. Hybrid algorithm for common best proximity points of some generalized nonself nonexpansive mappings. Math. Methods Appl. Sci. 2018, 41, 7655–7666. [Google Scholar] [CrossRef] [Scilit]
- Suparatulatorn, R.; Suantai, S. A new hybrid algorithm for global minimization of best proximity points in Hilbert spaces. Carpathian J. Math. 2019, 35, 95–102. [Google Scholar] [CrossRef] [Scilit]
- Chadli, O.; Ansari, Q.H.; Yao, J.C. Mixed equilibrium problems and anti-periodic solutions for nonlinear evolution equations. J. Optim. Theory Appl. 2016, 168, 410–440. [Google Scholar] [CrossRef] [Scilit]
- Chidume, C.; Nnakwe, M. A new Halpern-type algorithm for a generalized mixed equilibrium problem and a countable family of generalized nonexpansive-type maps. Carpathian J. Math. 2018, 34, 191–198. [Google Scholar] [CrossRef] [Scilit]
- Combettes, P.L.; Hirstoaga, S.A. Equilibrium programming in Hilbert spaces. J. Nonlinear Convex Anal. 2005, 6, 117–136. [Google Scholar]
- He, Z. The split equilibrium problem and its convergence algorithms. J. Inequalities Appl. 2012, 2012, 162. [Google Scholar] [CrossRef] [Scilit]
- Suantai, S.; Cholamjiak, P.; Cho, Y.J.; Cholamjiak, W. On solving split equilibrium problems and fixed point problems of nonspreading multi-valued mappings in Hilbert spaces. Fixed Point Theory Appl. 2016, 2016, 35. [Google Scholar] [CrossRef] [Scilit]
- Tiammee, J.; Suantai, S. On solving split best proximity point and equilibrium problems in Hilbert spaces. Carpathian J. Math. 2019, 35, 385–392. [Google Scholar] [CrossRef] [Scilit]
- Ceng, L.C.; Yao, J.C. A hybrid iterative scheme for mixed equilibrium problems and fixed point problems. J. Comput. Appl. Math. 2008, 214, 186–201. [Google Scholar] [CrossRef] [Scilit]
- Konnov, I.; Schaible, S.; Yao, J.C. Combined relaxation method for mixed equilibrium problems. J. Optim. Theory Appl. 2005, 126, 309–322. [Google Scholar] [CrossRef] [Scilit]
- Yao, Y.; Noor, M.A.; Zainab, S.; Liou, Y.C. Mixed equilibrium problems and optimization problems. J. Math. Anal. Appl. 2009, 354, 319–329. [Google Scholar] [CrossRef] [Scilit]
- Alvarez, F.; Attouch, H. An inertial proximal method for maximal monotone operators via discretization of a nonlinear oscillator with damping. Set-Valued Anal. 2001, 9, 3–11. [Google Scholar] [CrossRef] [Scilit]
- Maingé, P.E. Convergence theorems for inertial KM-type algorithms. J. Comput. Appl. Math. 2008, 219, 223–236. [Google Scholar] [CrossRef] [Scilit]
- Agarwal, R.P.; O’Regan, D.; Sahu, D. Fixed Point Theory for Lipschitzian-Type Mappings with Applications; Springer: Berlin/Heidelberg, Germany, 2009; Volume 6. [Google Scholar]
- Raj, V.S. Best proximity point theorems for non-self mappings. Fixed Point Theory 2013, 14, 447–454. [Google Scholar]
- Marino, G.; Xu, H.K. Weak and strong convergence theorems for strict pseudo-contractions in Hilbert spaces. J. Math. Anal. Appl. 2007, 329, 336–346. [Google Scholar] [CrossRef] [Scilit]
- Combettes, P.L. Quasi-Fejérian analysis of some optimization algorithms. In Studies in Computational Mathematics; Elsevier: Amsterdam, The Netherlands, 2001; Volume 8, pp. 115–152. [Google Scholar]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).