
Artificial Neural Network-Based Conveying Object Measurement Automation System Using Distance Sensor
Highlights
- An entry-level sensor combined with moving-window features and an ANN can achieve accurate and stable geometry measurements on a conveyor, despite limitations in sensor resolution and beam characteristics.
- The results indicate that entry-level sensors, when paired with appropriate feature engineering and machine learning, can serve as a practical alternative to expensive 3D scanners for inline logistics inspection and box-dimension measurement.
- The identified limitations highlight the need for future models that explicitly account for variations in the conveyor speed, sampling rate, and distance between the sensor and object.
Abstract
1. Introduction
- (1)
- Reliable geometry measurement with a single entry-level distance sensor: We propose a machine learning-based measurement approach that achieves reliable geometry estimation using only one low-cost distance sensor under various transfer conditions, avoiding the cost and integration burden of professional 3D scanners or multi-camera systems.
- (2)
- Systematic framework for geometry measurement: We introduce the systematic framework that combines signal processing, robust feature extraction, and machine learning–based modeling to mitigate noise and environmental variability, improving both accuracy and robustness.
2. Sign and Motivating Example
2.1. Measurement System Design
2.2. Data Description
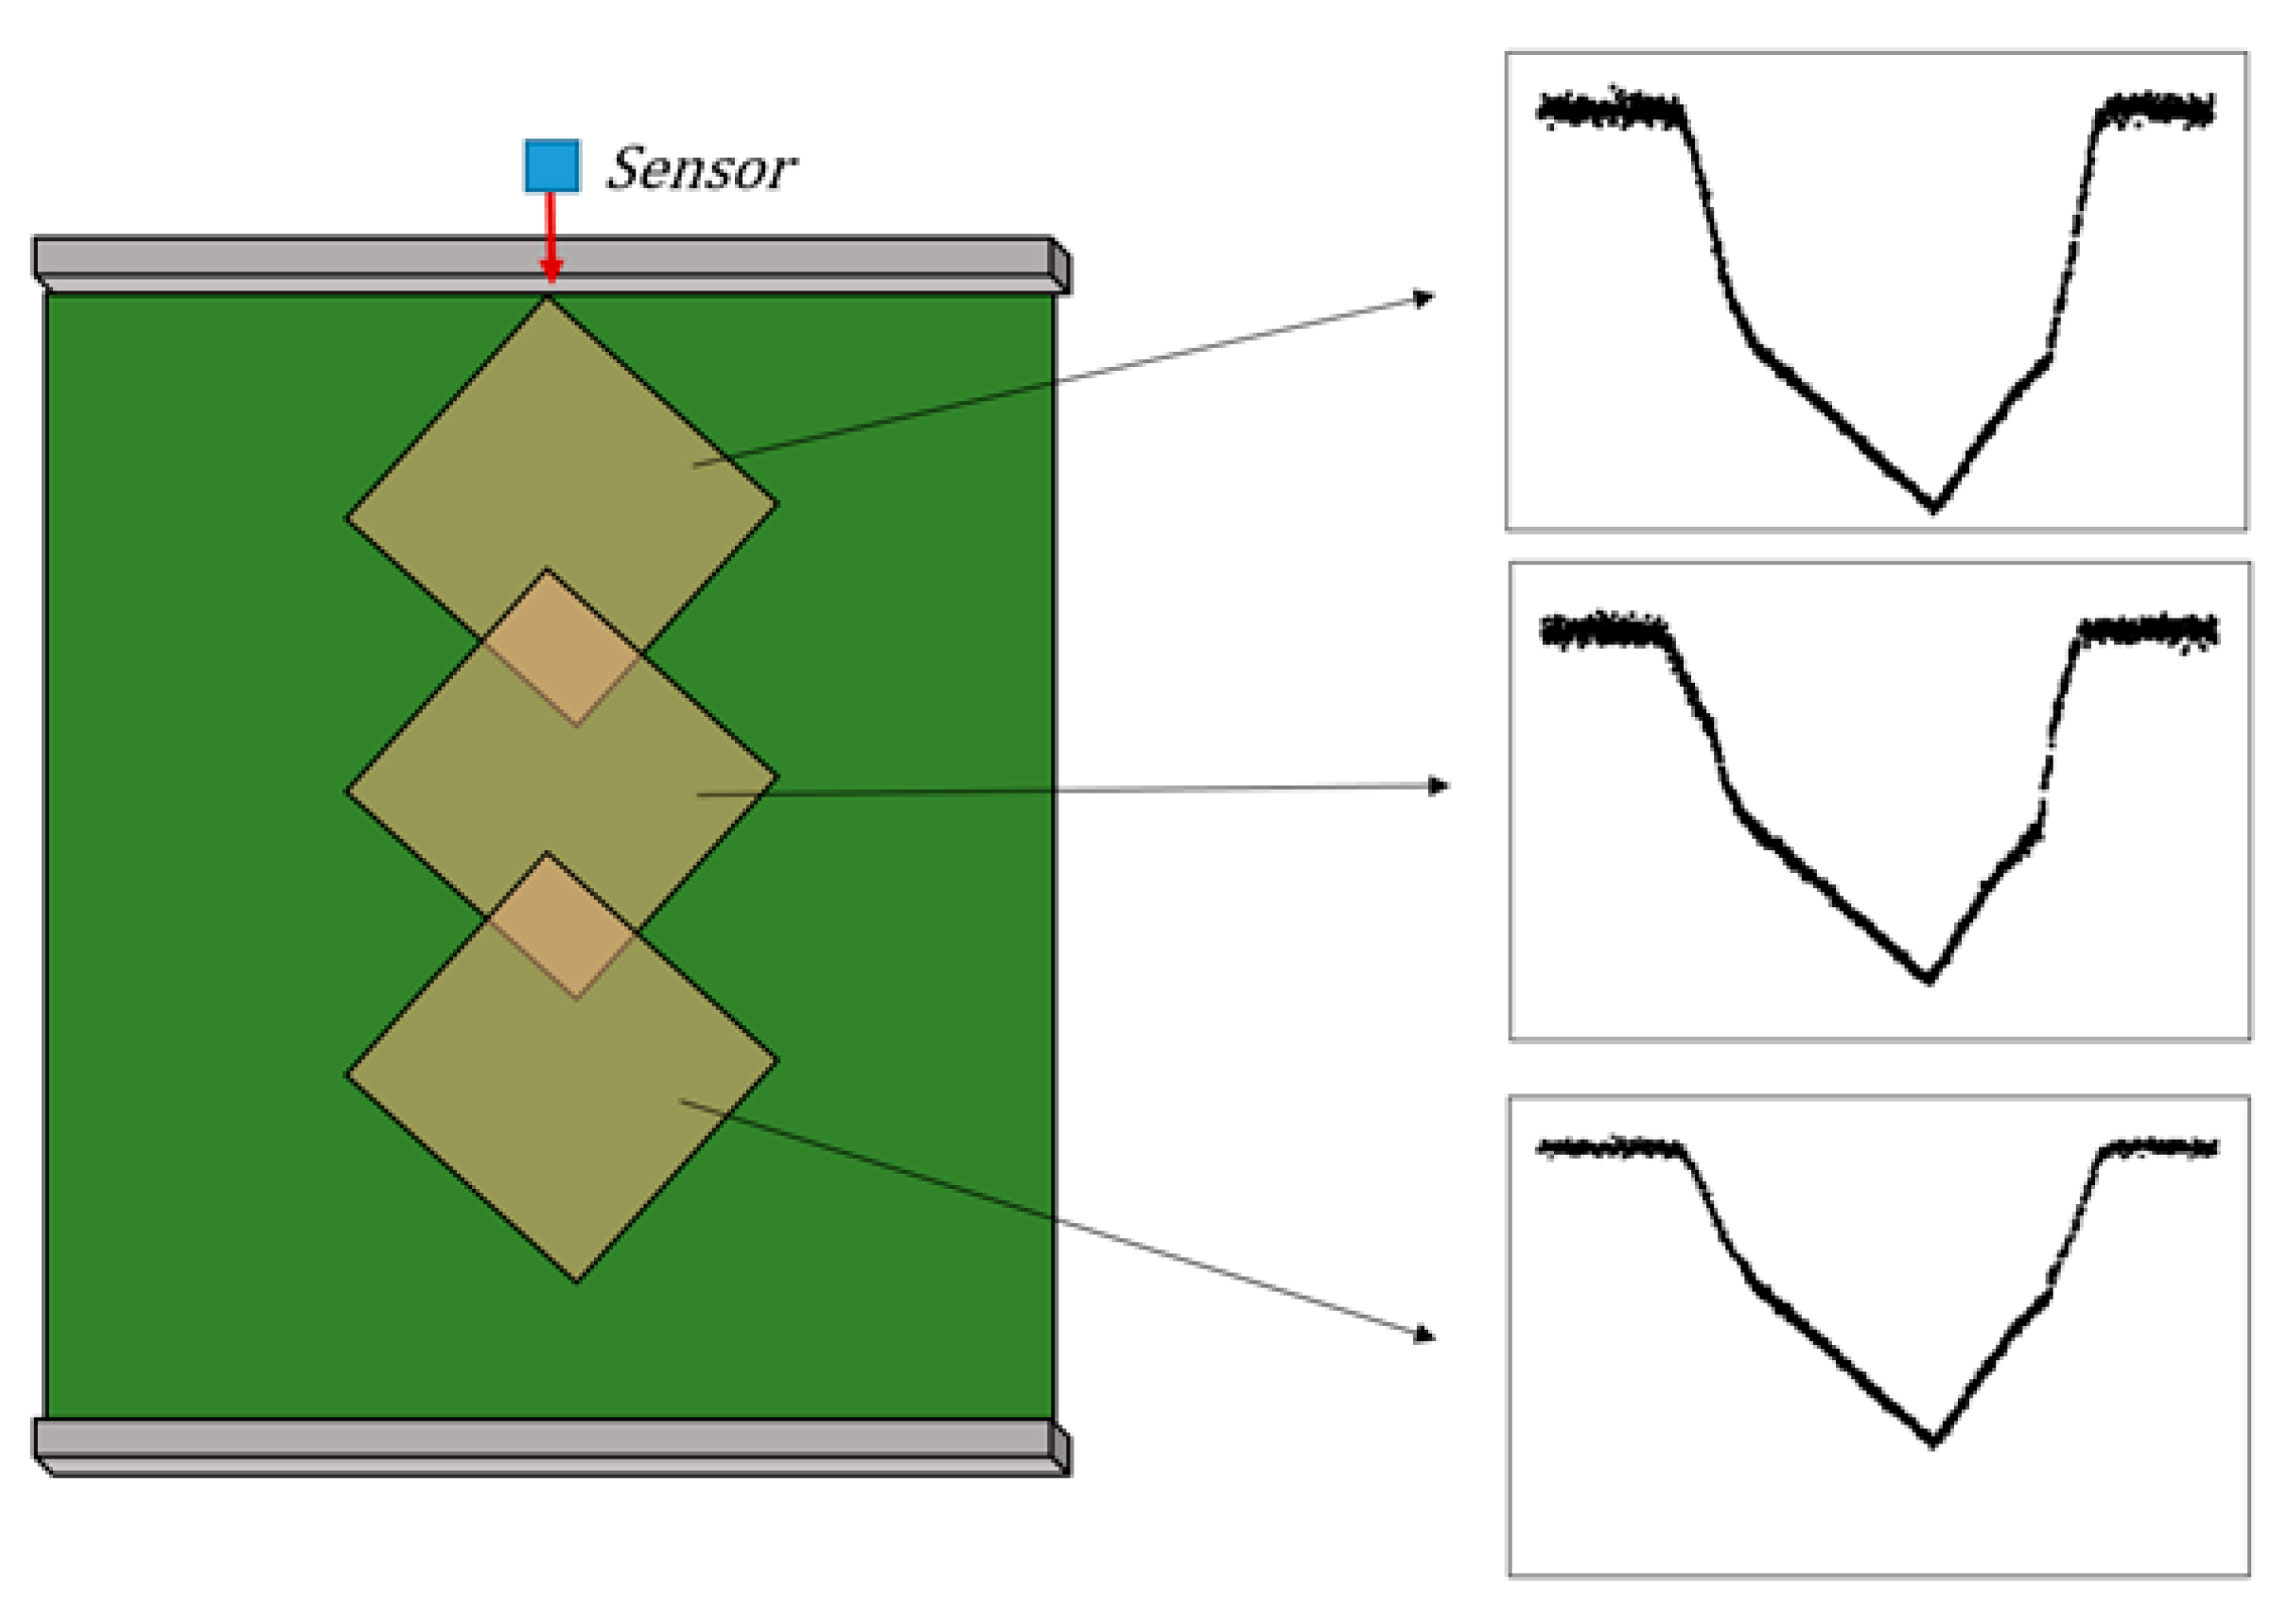
2.3. Motivating Example
3. Proposed Model for Geometry Measurement
4. Experiments
4.1. Design
4.2. Results
5. Conclusions
5.1. Limitations
5.2. Future Work
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
Abbreviations
| AI | Artificial intelligence |
| IoT | Internet of things |
| DOF | Degree of freedom |
| LSR | Linear spline regression |
| ANNs | Artificial neural networks |
| IT | Information technology |
| PSDs | Position sensitive detectors |
| ToF | Time of flight |
| DAQ | Data acquisition |
| CUSUM | Cumulative sum |
| SVR | Support vector regression |
| RF | Random forest |
| MAE | Mean absolute error |
| SDE | Standard deviation error |
| CNNs | Convolutional neural networks |
References
- Raaj, Y.; Nair, S.; Knoll, A. Precise measurement of cargo boxes for gantry robot palletization in large scale workspaces using low-cost RGB-D sensors. In Computer Vision—ACCV 2016; Lai, S.H., Lepetit, V., Nishino, K., Sato, Y., Eds.; Springer: Cham, Switzerland, 2017; Volume 10117, pp. 472–486. [Google Scholar]
- Lu, L.; Yang, J.; Liang, J.; Zhang, A. 3D reconstruction of grabbed objects using a single image based on palletizing task. In ICGG 2020—Proceedings of the 19th International Conference on Geometry and Graphics; Springer: Cham, Switzerland, 2021; pp. 518–529. [Google Scholar]
- Zhang, B.; Skaar, S.B. Robotic de-Palletizing Using Uncalibrated Vision and 3D Laser-Assisted Image Analysis. In Proceedings of the 2009 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), St. Louis, MO, USA, 10–15 October 2009; pp. 3820–3825. [Google Scholar]
- Básaca-Preciado, L.C.; Sergiyenko, O.Y.; Rodríguez-Quinonez, J.C.; García, X.; Tyrsa, V.V.; Rivas-Lopez, M.; Hernandez-Balbuena, D.; Mercorelli, P.; Podrygalo, M.; Gurko, A.; et al. Optical 3D laser measurement system for navigation of autonomous mobile robot. Opt. Lasers Eng. 2014, 54, 159–169. [Google Scholar] [CrossRef] [Scilit]
- Klingbeil, L.; Nieuwenhuisen, M.; Schneider, J.; Eling, C.; Droeschel, D.; Holz, D.; Läbe, T.; Förstner, W.; Behnke, S.; Kuhlmann, H. Towards Autonomous Navigation of an UAV-Based Mobile Mapping System. In Proceedings of the International Conference on Machine Control & Guidance (MCG), Braunschweig, Germany, 25–27 March 2014. [Google Scholar]
- Wang, H.; Wang, B.; Liu, B.; Meng, X.; Yang, G. Pedestrian recognition and tracking using 3D LiDAR for autonomous vehicle. Robot. Auton. Syst. 2017, 88, 71–78. [Google Scholar] [CrossRef] [Scilit]
- Shahdib, F.; Bhuiyan, M.W.U.; Hasan, M.K.; Mahmud, H. Obstacle detection and object size measurement for autonomous mobile robot using sensor. Int. J. Comput. Appl. 2013, 66, 28–33. [Google Scholar]
- Riffo, V.; Hidalgo, R. Active inspection of objects to detect possible damage and measure their volume using 3D reconstruction. Measurement 2022, 199, 111541. [Google Scholar] [CrossRef] [Scilit]
- Deng, F.; Liu, C.; Sze, W.; Deng, J.; Fung, K.S.; Lam, E.Y. An INSPECT measurement system for moving objects. IEEE Trans. Instrum. Meas. 2015, 64, 63–74. [Google Scholar] [CrossRef] [Scilit]
- Traxler, L.; Ginner, L.; Breuss, S.; Blaschitz, B. Experimental comparison of optical inline 3D measurement and inspection systems. IEEE Access 2021, 9, 53952–53963. [Google Scholar] [CrossRef] [Scilit]
- 3Space. Advantages & Disadvantages of 3D Laser Scanning. Available online: https://3space.com/blog/advantages-disadvantages-of-3d-laser-scanning/ (accessed on 2 January 2020).
- Mustafah, Y.M.; Noor, R.; Hasbi, H.; Azma, A.W. Stereo Vision Images Processing for Real-Time Object Distance and Size Measurements. In Proceedings of the 2012 International Conference on Computer and Communication Engineering (ICCCE), Kuala Lumpur, Malaysia, 3–5 July 2012; pp. 659–663. [Google Scholar]
- Mustafah, Y.M.; Azman, A.W.; Ani, M.H. Object distance and size measurement using stereo vision system. Adv. Mater. Res. 2013, 622, 1373–1377. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Yu, X.; Chen, S.; Tang, W. Object localization and size measurement using networked address event representation imagers. IEEE Sens. J. 2016, 16, 2894–2895. [Google Scholar] [CrossRef] [Scilit]
- Ma, Y.; Li, Q.; Xing, J.; Huo, G.; Liu, Y. An intelligent object detection and measurement system based on trinocular vision. IEEE Trans. Circuits Syst. Video Technol. 2020, 30, 711–724. [Google Scholar] [CrossRef] [Scilit]
- Vo-Le, C.; Van Muoi, P.; Son, N.H.; Van San, N.; Duong, V.K.; Huyen, N.T. Automatic Method for Measuring Object Size Using 3D Camera. In Proceedings of the 2020 IEEE 8th International Conference on Communications and Electronics (ICCE), Phu Quoc, Vietnam, 13–15 January 2021; pp. 365–369. [Google Scholar]
- Zhou, Y.; Li, Q.; Ye, Q.; Yu, D.; Yu, Z.; Liu, Y. A binocular vision-based underwater object size measurement paradigm: Calibration–Detection–Measurement (CDM). Measurement 2023, 216, 112997. [Google Scholar] [CrossRef] [Scilit]
- Kainz, O.; Jakab, F.; Horečný, M.W.; Cymbalák, D. Estimating the Object Size from Static 2D Image. In Proceedings of the 2015 International Conference and Workshop on Computing and Communication (IEMCON), Vancouver, BC, Canada, 15–17 October 2015; pp. 1–5. [Google Scholar]
- Pu, L.; Tian, R.; Wu, H.C.; Yan, K. Novel Object-Size Measurement Using the Digital Camera. In Proceedings of the 2016 IEEE Advanced Information Management, Communicates, Electronic and Automation Control Conference (IMCEC), Xi’an, China, 3–5 October 2016; pp. 543–548. [Google Scholar]
- Othman, N.A.; Salur, M.U.; Karakose, M.; Aydin, I. An Embedded Real-Time Object Detection and Measurement of Its Size. In Proceedings of the 2018 International Conference on Artificial Intelligence and Data Processing (IDAP), Malatya, Turkey, 28–30 September 2018; pp. 1–4. [Google Scholar]
- Roh, D.W.; Jeon, J.W. Real-Time Object Size Measurement. In Proceedings of the 2019 International SoC Design Conference (ISOCC), Jeju, Republic of Korea, 6–9 October 2019; pp. 285–286. [Google Scholar]
- Ankad, S.S.; Raj, B.S.; Nasreen, A.; Mathur, S.; Kumar, P.R.; Sreelakshmi, K. Object Size Measurement from CCTV Footage Using Deep Learning. In Proceedings of the 2021 IEEE International Conference on Computation System and Information Technology for Sustainable Solutions (CSITSS), Bengaluru, India, 16–18 December 2021; pp. 1–5. [Google Scholar]
- Li, R.; Chen, G.; Dai, Y.; Xia, G.; Zhang, J.; Cui, L.; Yin, X. Object dimension measurement based on monocular endoscope and 5-DOF sensor. Measurement 2023, 206, 112293. [Google Scholar] [CrossRef] [Scilit]
- Lee, J.M. Real distance measurement using object detection of artificial intelligence. Turk. J. Comput. Math. Educ. 2021, 12, 557–563. [Google Scholar]
- Xu, Z.; Zhou, H.; Peng, S.; Lin, H.; Guo, H.; Shao, J.; Bao, H. Towards Depth Foundation Model: Recent Trends in Vision-Based Depth Estimation. arXiv 2025, arXiv:2507.11540. [Google Scholar] [CrossRef] [Scilit]
- Piccinelli, L.; Sakaridis, C.; Segu, M.; Yang, Y.H.; Li, S.; Abbeloos, W.; Van Gool, L. UniK3D: Universal Camera Monocular 3D Estimation. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Nashville, TN, USA, 11–15 June 2025; pp. 1028–1039. [Google Scholar]
- Liu, Y.; Chen, X. Monocular meta-imaging camera sees depth. Light Sci. Appl. 2025, 14, 5. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kim, J.M.; Do, Y.T. PSD sensor array design for the 3D measurement of moving objects. J. Sens. Sci. Technol. 2008, 17, 106–113. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.; Wang, H.; Dong, H. A survey of deep learning-driven 3D object detection: Sensor modalities, technical architectures, and applications. Sensors 2025, 25, 3668. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yuan, S.; Ma, C.; Fetaya, E.; Mueller, T.; Naveh, D.; Zhang, F.; Xia, F. Geometric deep optical sensing. Science 2023, 379, eade1220. [Google Scholar] [CrossRef] [Scilit]
- Ma, J.; Wang, W.; Jin, Q. A Survey of Deep Learning for Geometry Problem Solving. arXiv 2025, arXiv:2507.11936. [Google Scholar] [CrossRef] [Scilit]
- VL53L0X. Time-of-Flight (ToF) Ranging Sensor. Available online: https://www.st.com/en/imaging-and-photonics-solutions/vl53l0x.html (accessed on 10 February 2025).
- Park, S.H.; Heo, H.B.; Kang, J. Shape inference of conveyor objects with depth sensor analysis. J. Korean Inst. Inf. Technol. 2021, 19, 45–53. [Google Scholar] [CrossRef] [Scilit]
- Arduino Older Boards. Available online: https://docs.arduino.cc/retired/other/arduino-older-boards (accessed on 4 February 2025).
- 3D Scanner Price Ranges. Available online: https://mfg.trimech.com/3d-scanner-price-buyers-guide/ (accessed on 2 January 2025).
- Chun, Y.S.; Suh, Y.S.; Ro, Y.S. Three Dimensional Information Detective Instrument Development Using Laser and Computer Vision. In Proceedings of the KIEE Conference, Seoul, Republic of Korea, 18–20 July 2005; pp. 2504–2506. [Google Scholar]
- Solow, A.R. Testing for climate change: An application of the two-phase regression model. J. Appl. Meteorol. Climatol. 1987, 26, 1401–1405. [Google Scholar] [CrossRef] [Scilit]
- Ryoo, S.B.; Kim, Y.H.; Kwon, T.H.; Park, I.S. Inhomogeneities in Korean climate data (I): Due to site relocation. Atmosphere 2006, 16, 215–223. [Google Scholar]
- Coyle, D.; Prasad, G.; McGinnity, T.M. A time-series prediction approach for feature extraction in a brain–computer interface. IEEE Trans. Neural Syst. Rehabil. Eng. 2005, 13, 461–467. [Google Scholar] [CrossRef] [PubMed]
- Hota, H.S.; Handa, R.; Shrivas, A.K. Time series data prediction using sliding window based RBF neural network. Int. J. Comput. Intell. Res. 2017, 13, 1145–1156. [Google Scholar]

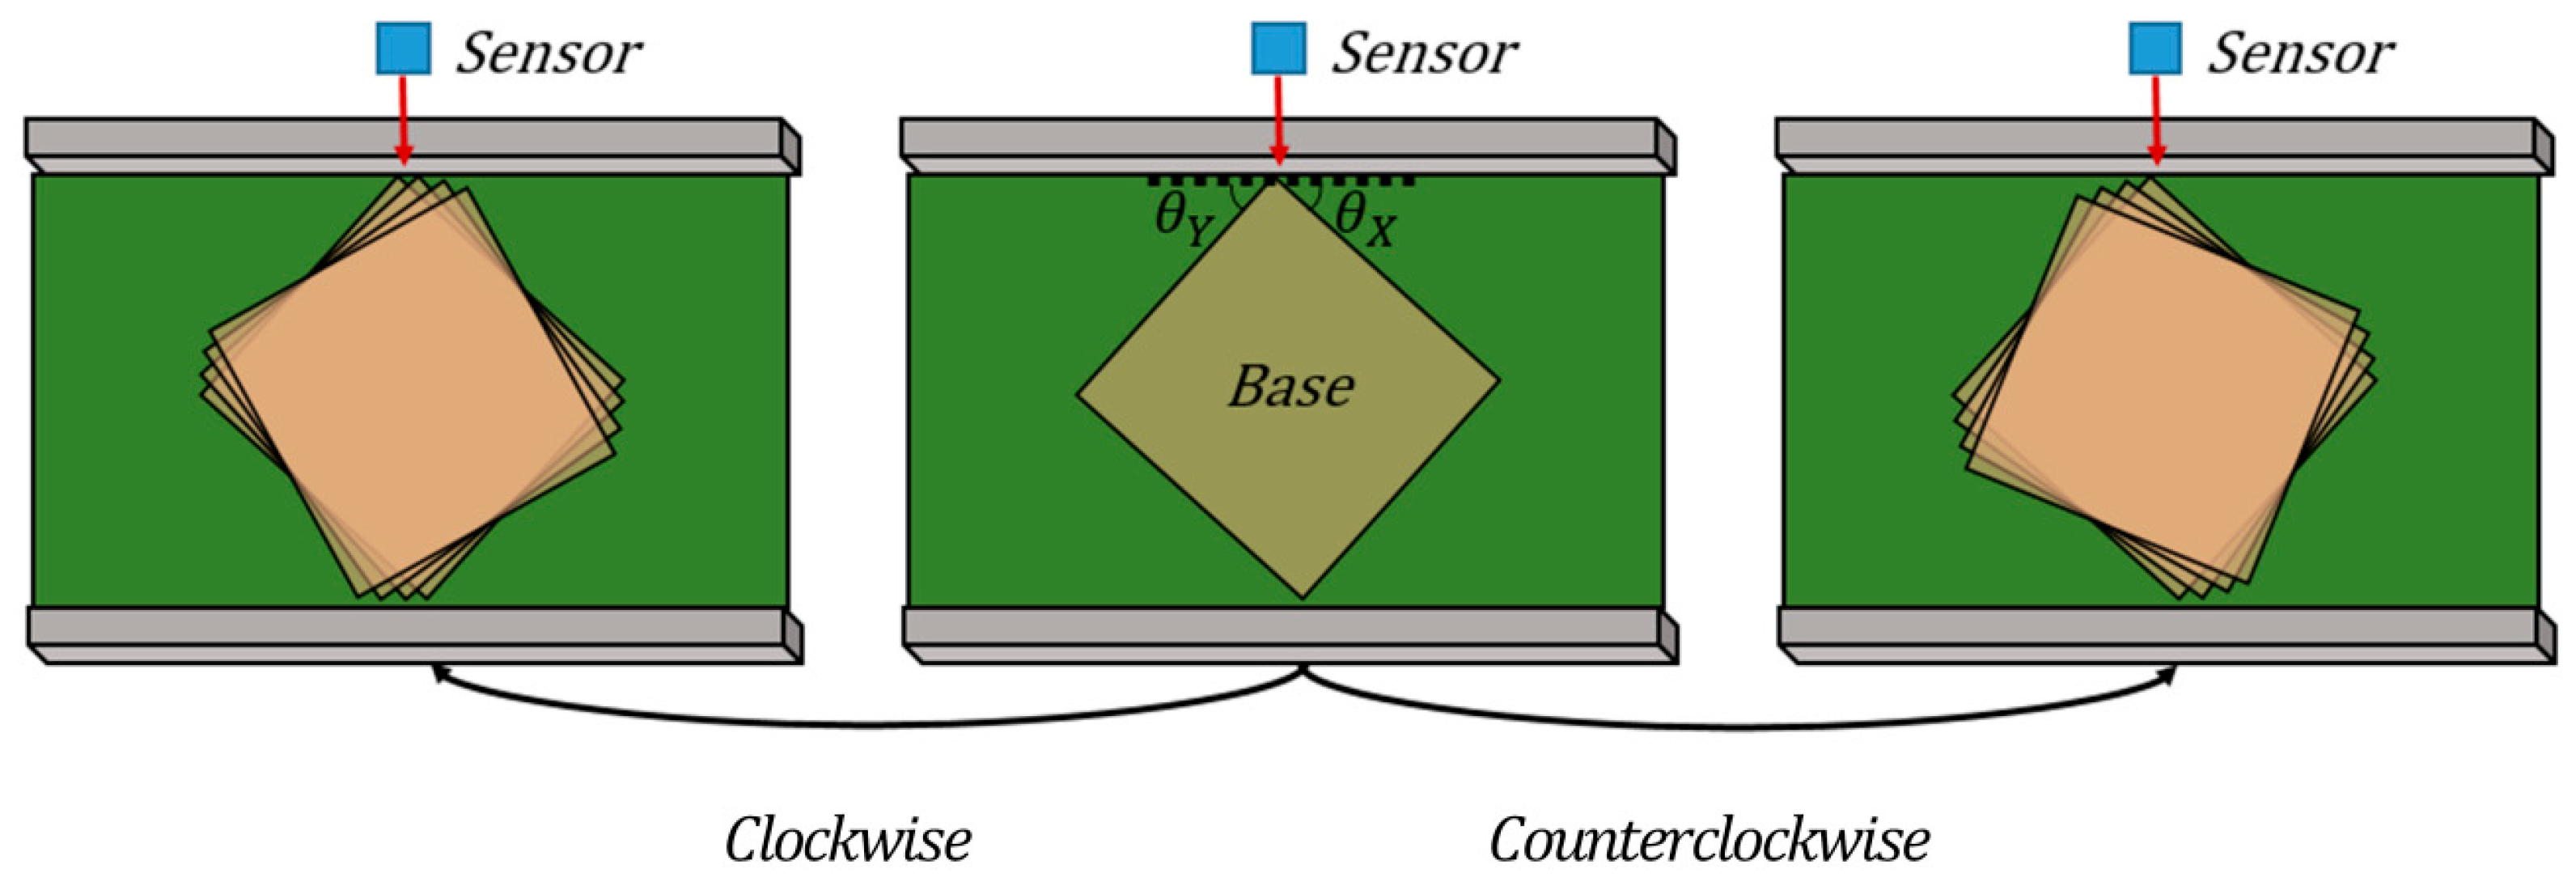




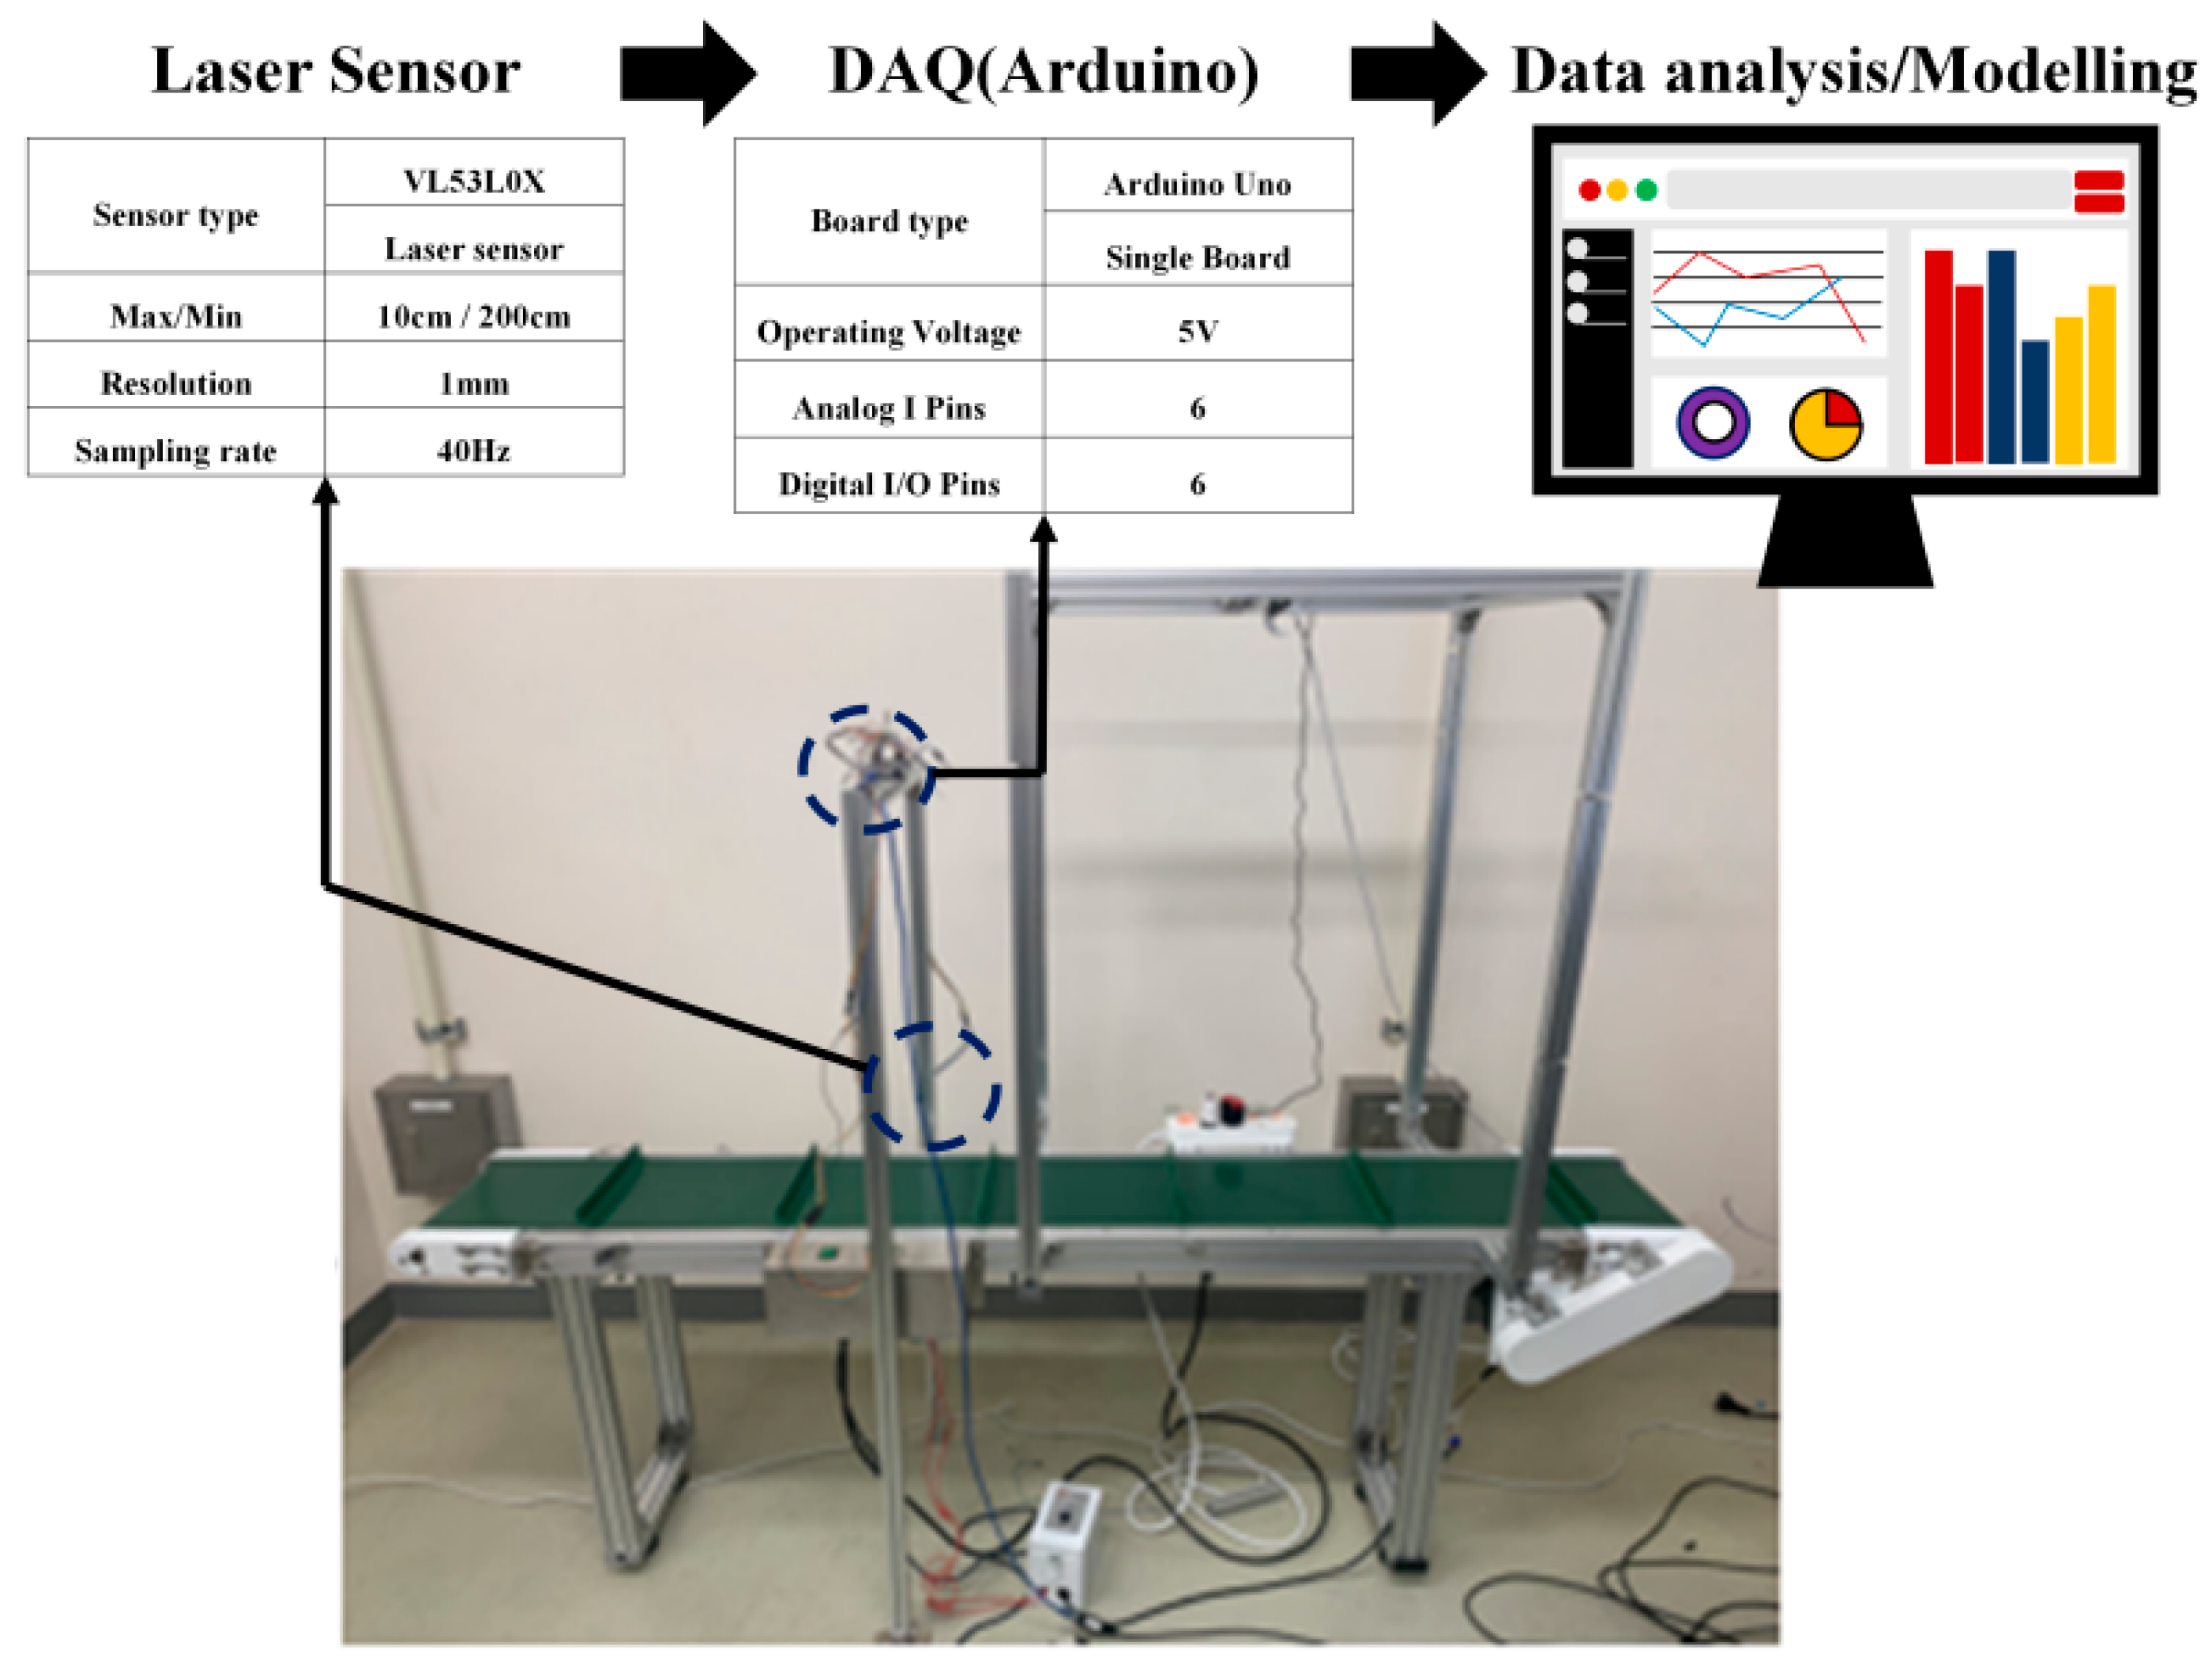
| Main Components | Quantity | Price (USD) |
|---|---|---|
| VL53L0X | 1 | 23 |
| Arduino Uno | 1 | 27 |
| Conveyor belt | 1 | 615 |
| (Degree) | (Degree) | Size | Iteration | |||
|---|---|---|---|---|---|---|
| No. | Edge 1 (mm) | Edge 2 (mm) | ||||
| 16.71 | 73.29 | 1 | 220 | 191 | 10 times per size | |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
| 21.71 | 68.29 | 1 | 220 | 191 | 10 times per size | |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
| 26.71 | 63.29 | 1 | 220 | 191 | 10 times per size | |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
| 31.71 | 58.29 | 1 | 220 | 191 | 10 times per size | |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
| Base (B) | 36.71 | 53.29 | 1 | 220 | 191 | 10 times per size |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
| 41.71 | 48.29 | 1 | 220 | 191 | 10 times per size | |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
| 46.71 | 43.29 | 1 | 220 | 191 | 10 times per size | |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
| 51.71 | 38.29 | 1 | 220 | 191 | 10 times per size | |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
| 56.71 | 33.29 | 1 | 220 | 191 | 10 times per size | |
| 2 | 270 | 180 | ||||
| 2-1 | 350 | 251 | ||||
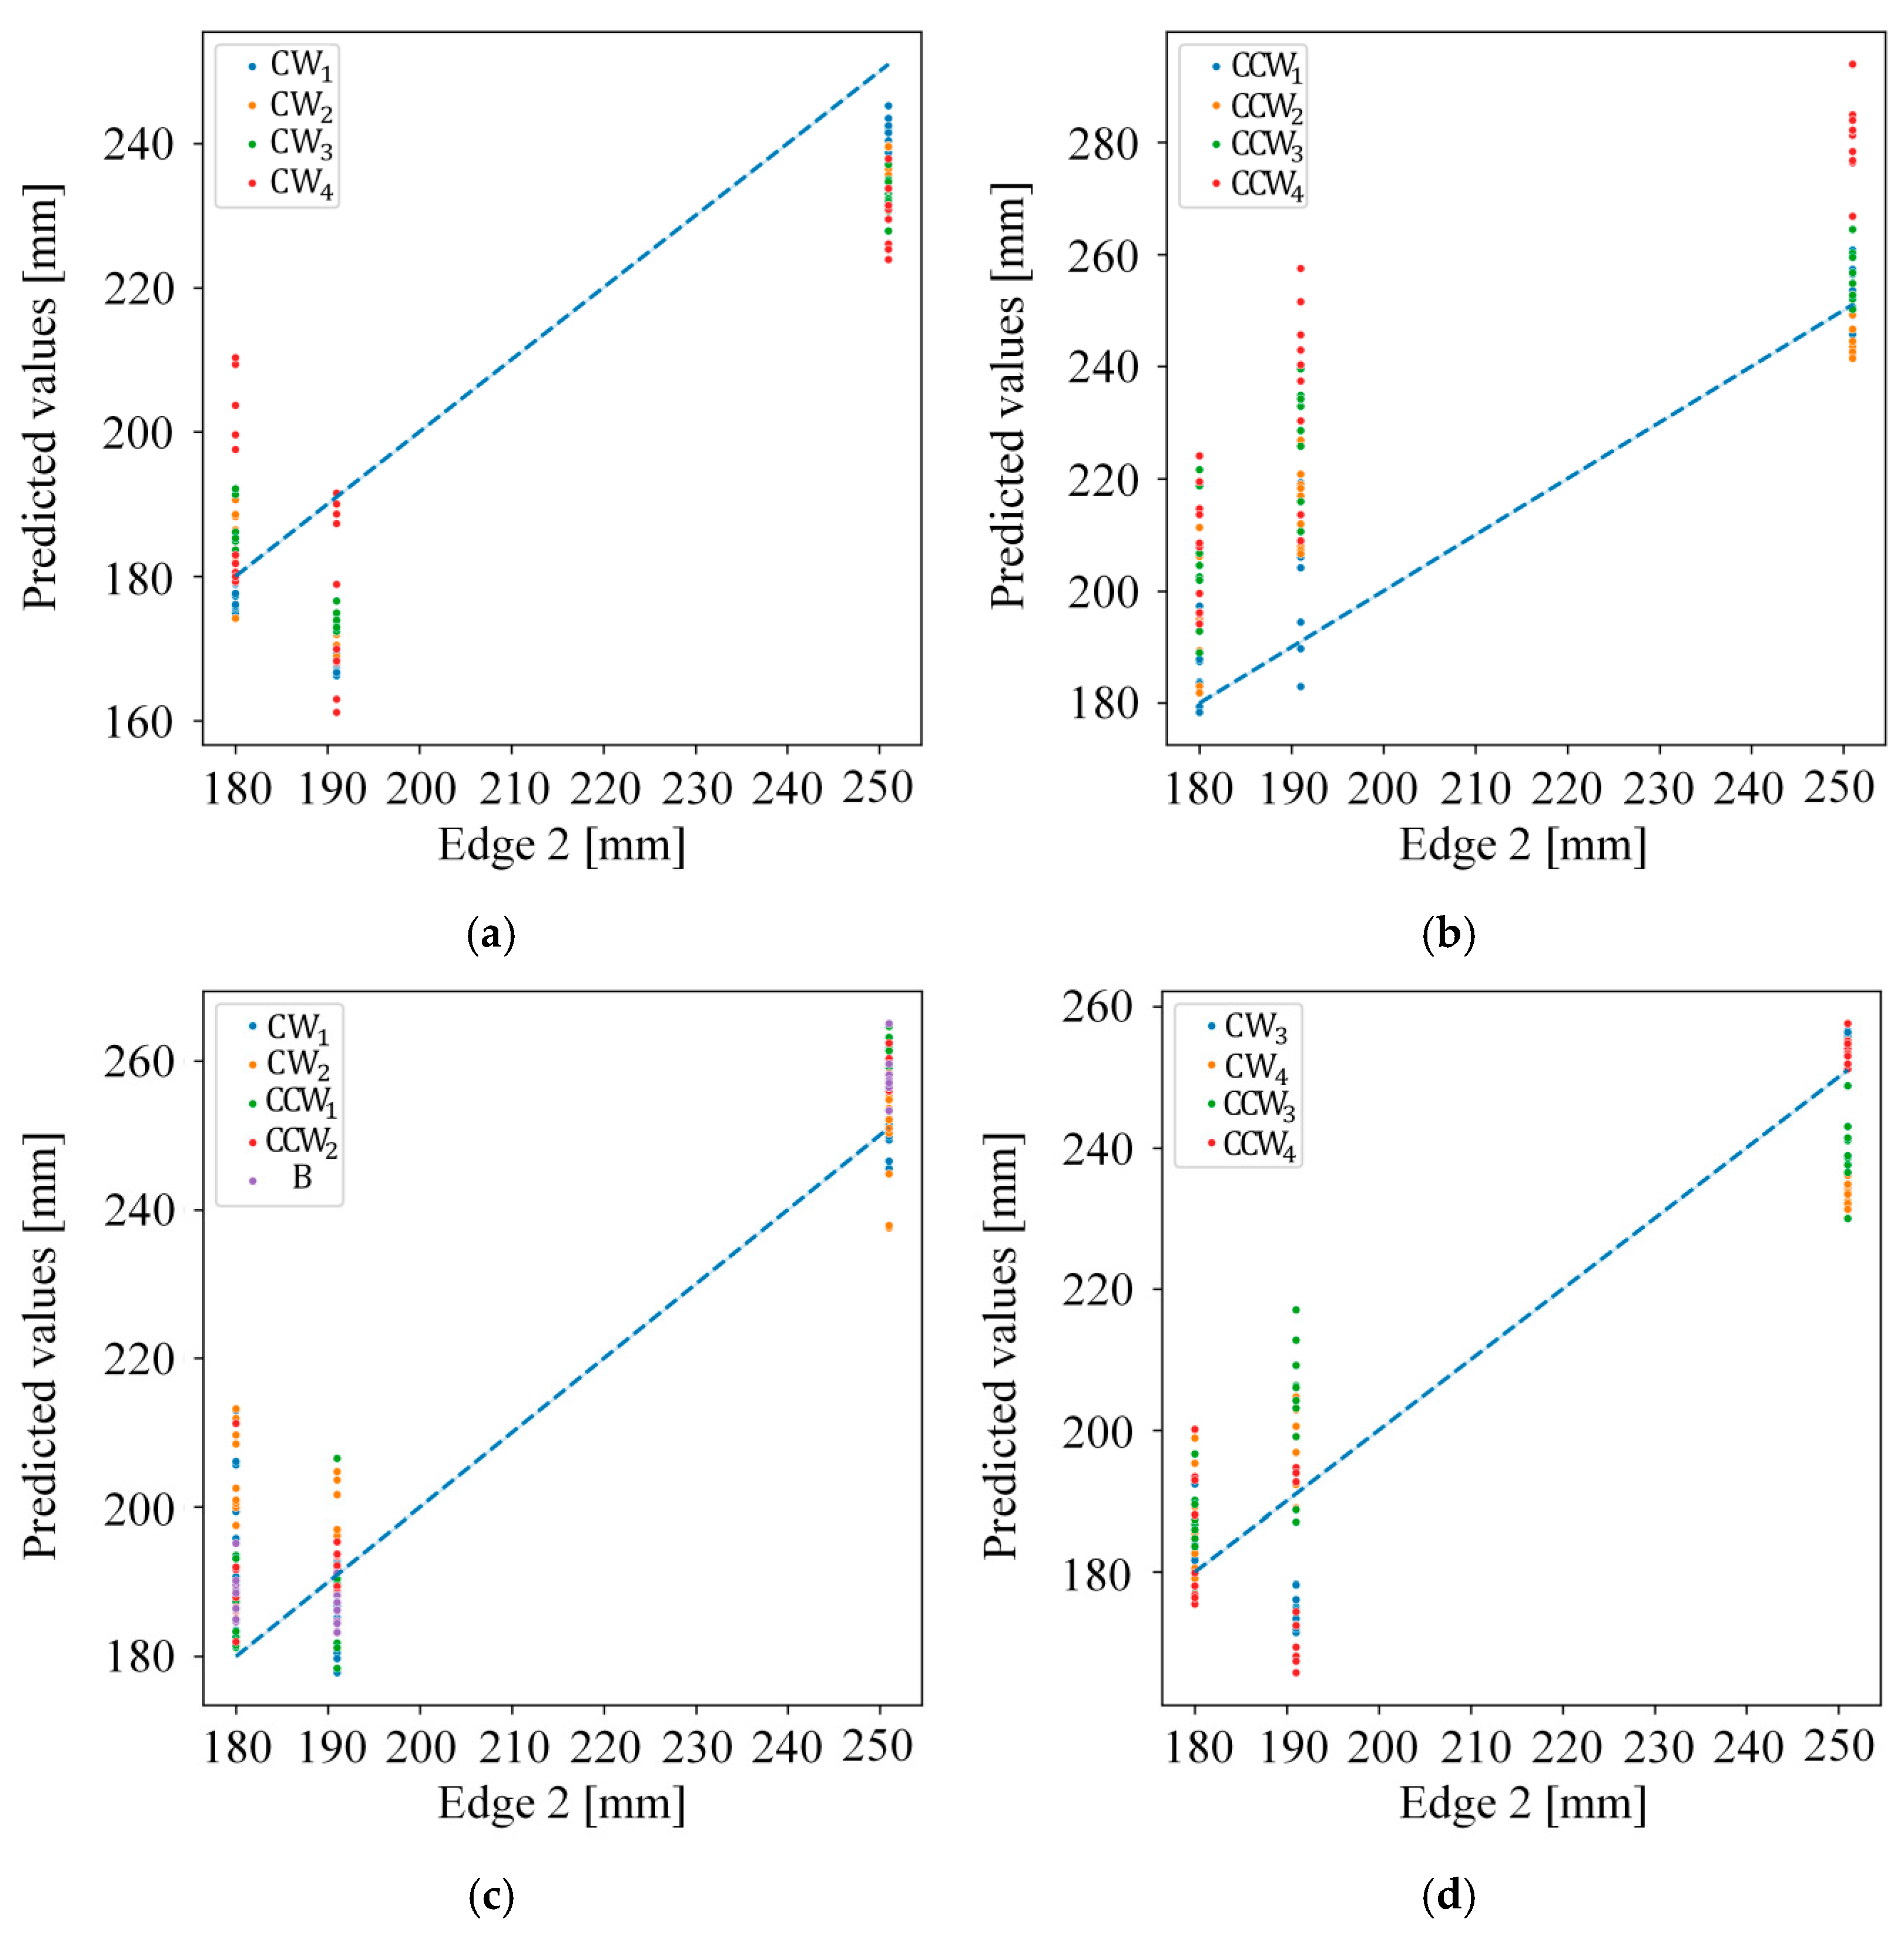
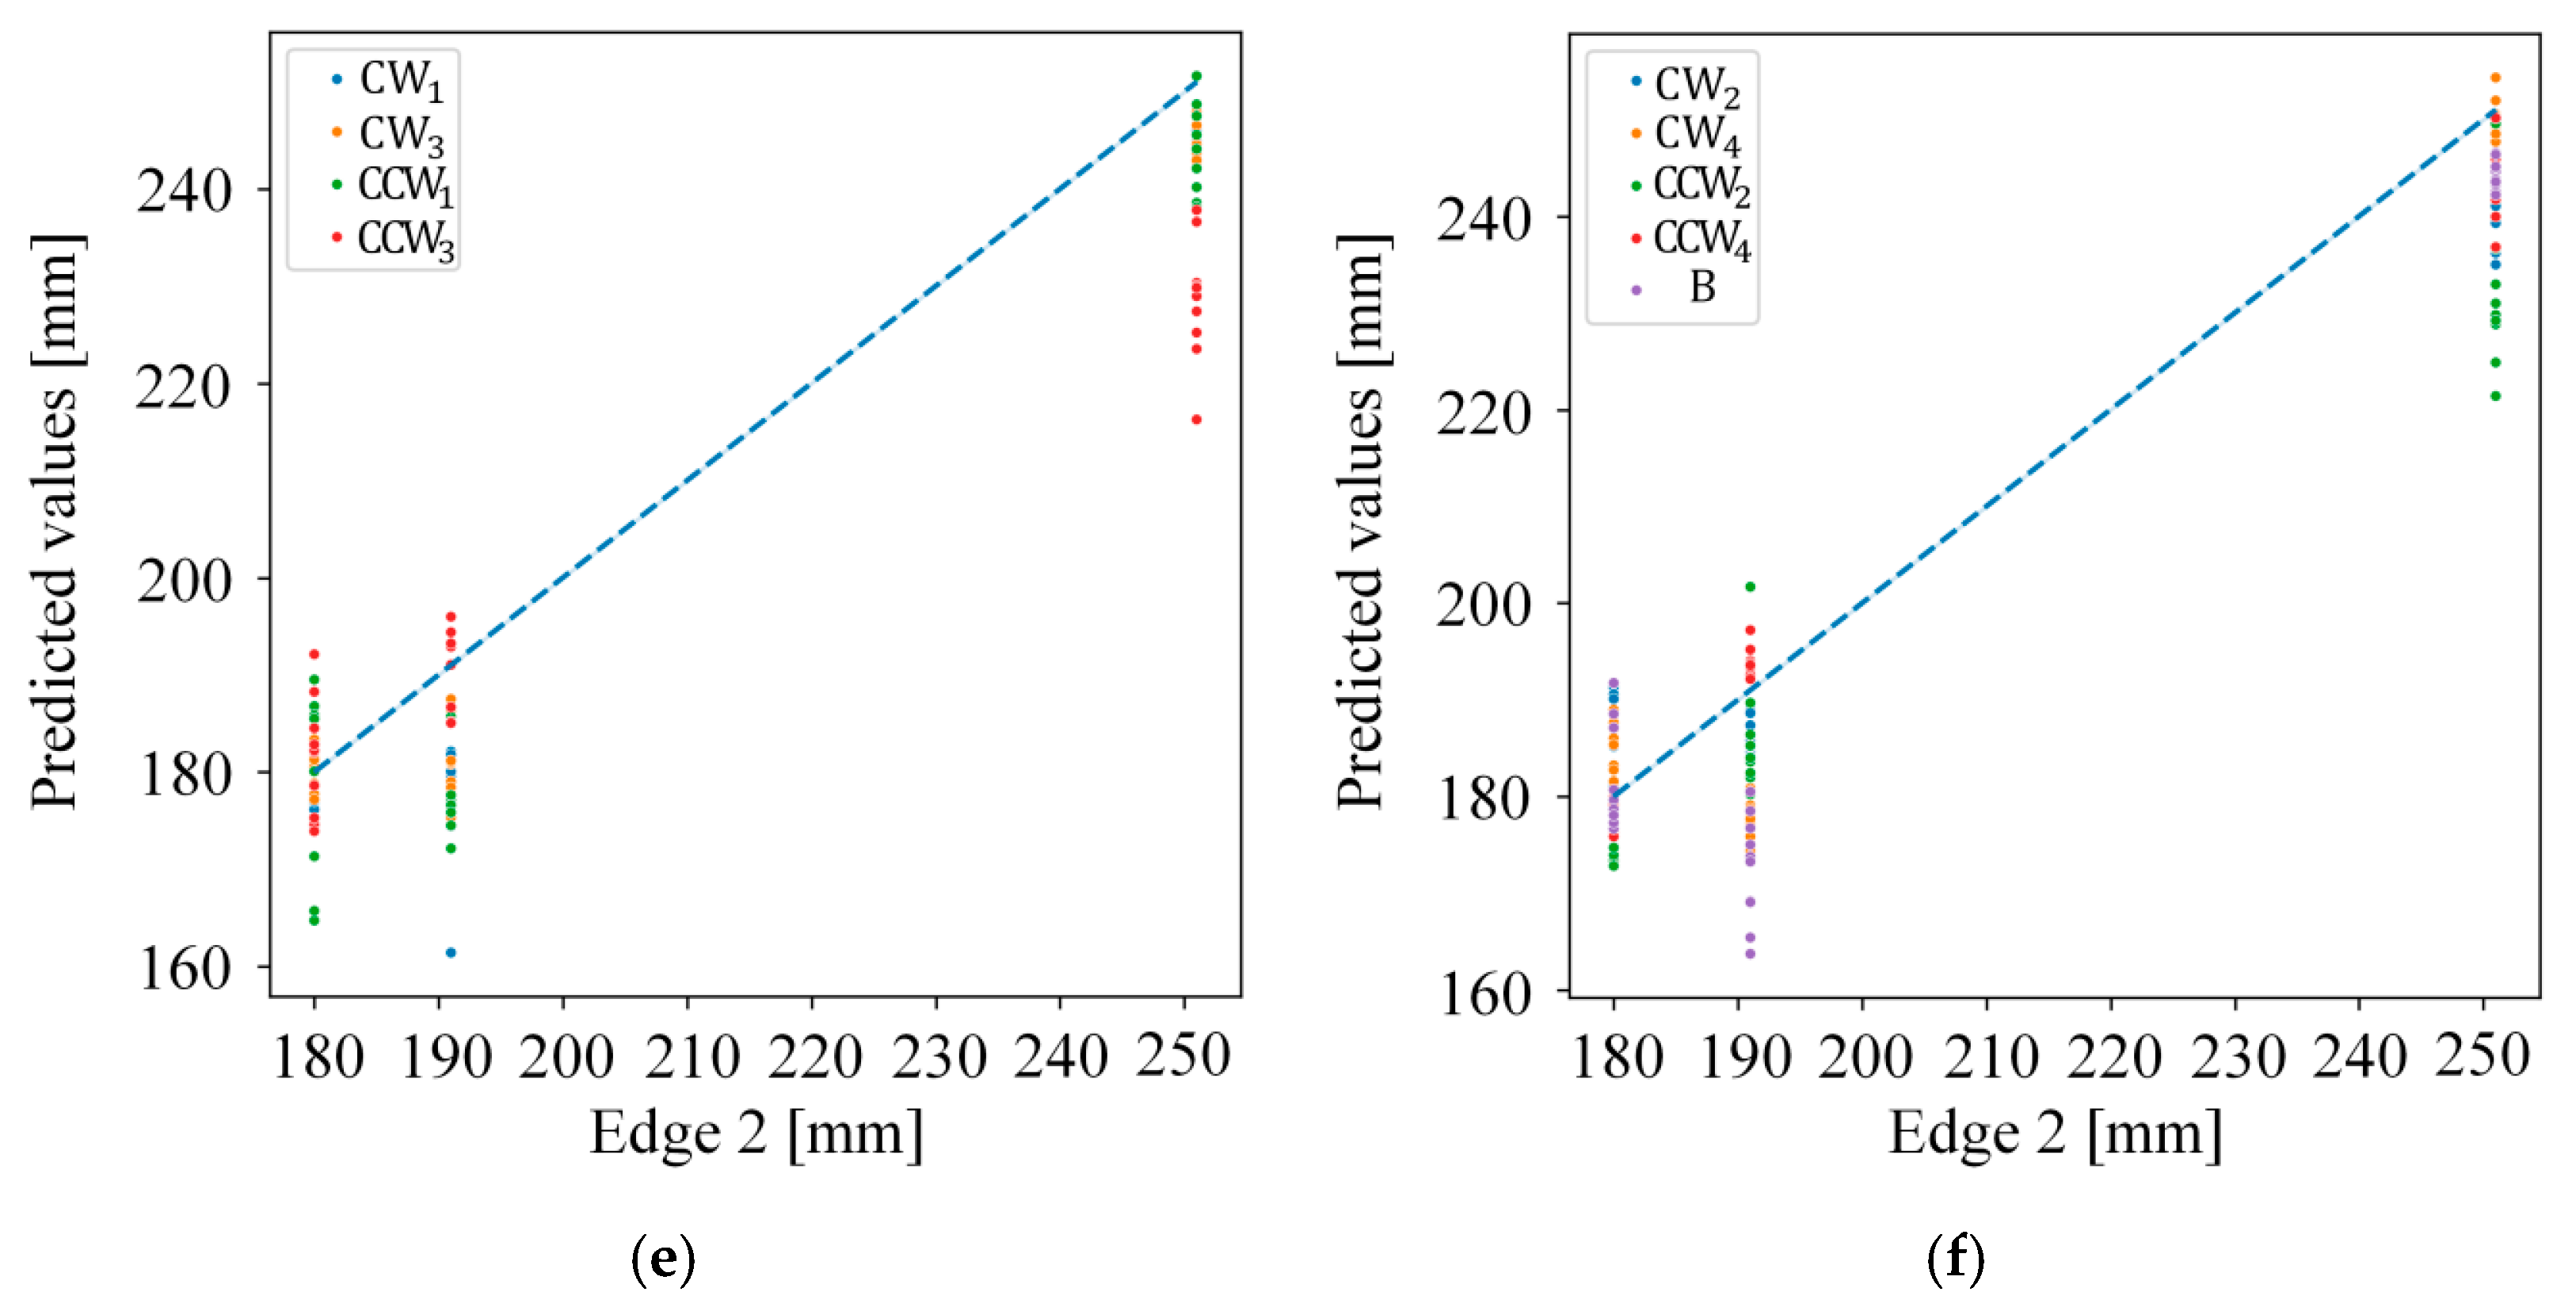
| Experiments | Training Datasets | Test Datasets |
|---|---|---|
| Experiment 1 | ||
| Experiment 2 | ||
| Experiment 3 | ||
| Experiment 4 | ||
| Experiment 5 | ||
| Experiment 6 |
| Model | Hyper-Parameter | Value | Search Range | |
|---|---|---|---|---|
| Edge 1 | Edge 2 | |||
| ANN | Hidden layers | 4 | 4 | [1~10], step = +1 |
| Hidden nodes | 160 | 20 | [20~140], step = +20 | |
| Learning rate | 0.01 | 0.01 | [0.00001~0.1], step = ×10 | |
| RF | Estimators | 50 | 25 | [25~150], step = +25 |
| Max features | 8 | 2 | [2~10], step = +2 | |
| SVR | Kernel | Linear | RBF | [Linear, Poly, RBF] |
| Cost | 0.1 | 100 | [0.001~100], step = ×10 | |
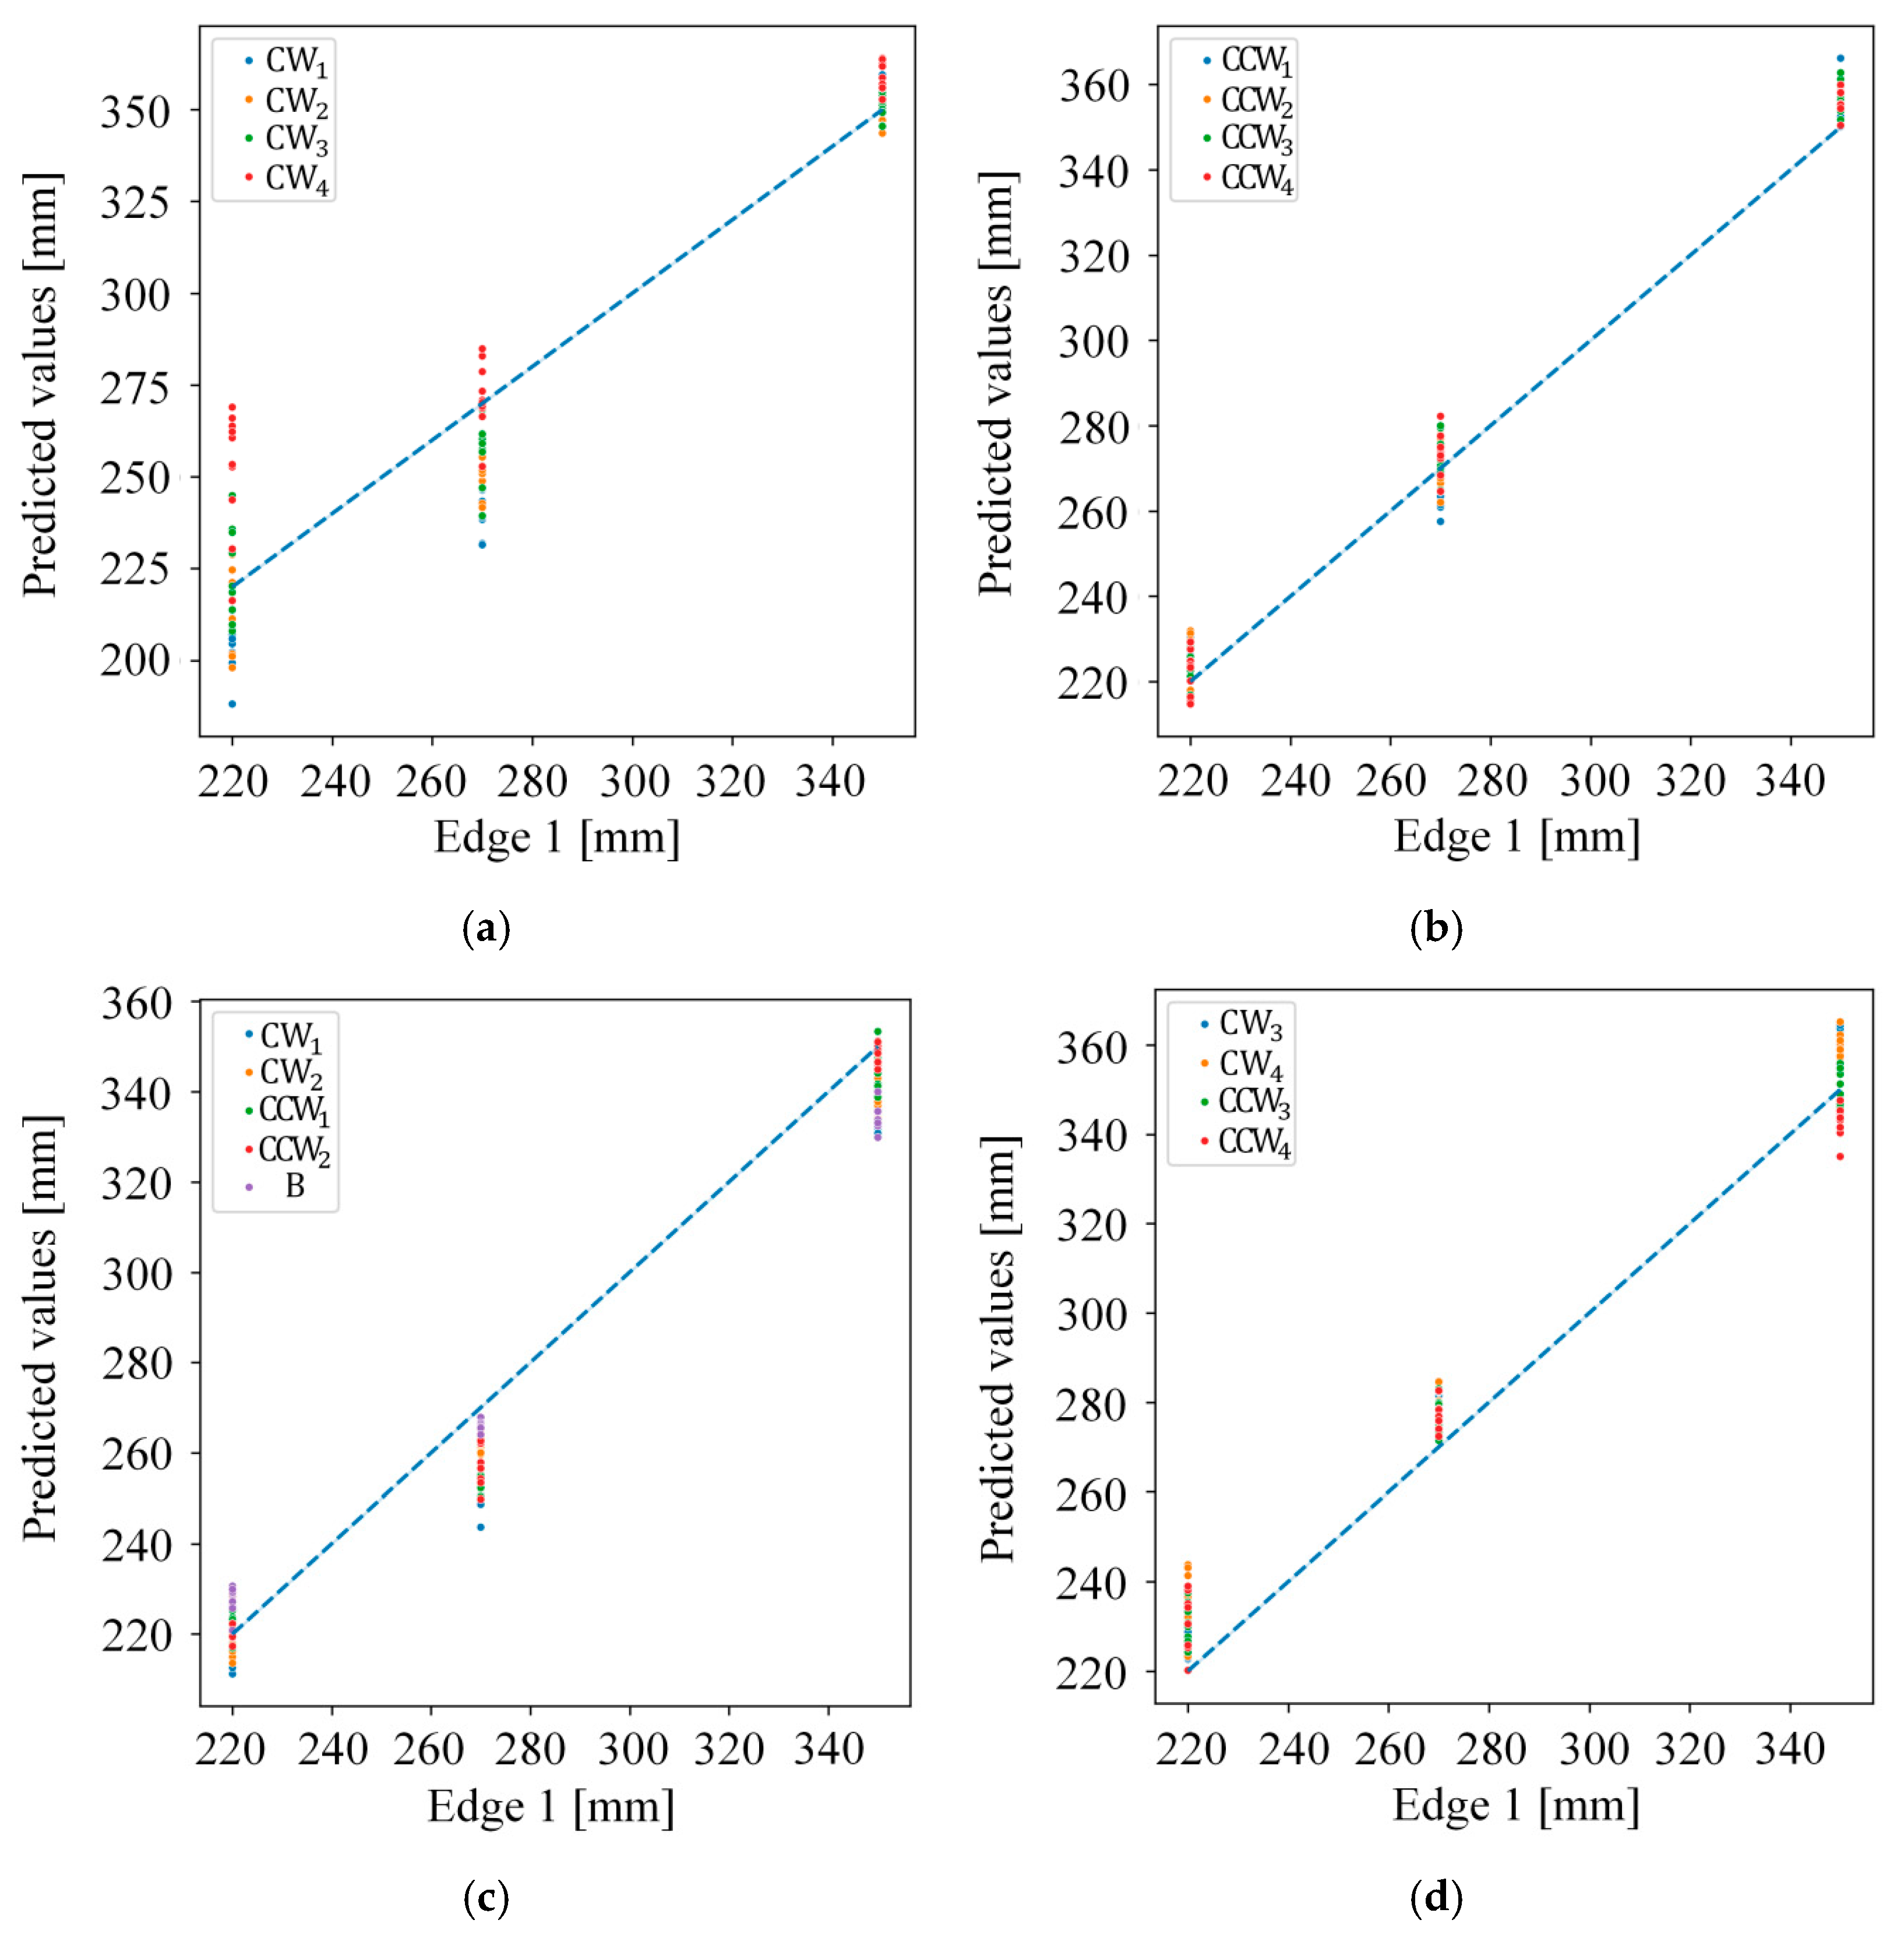
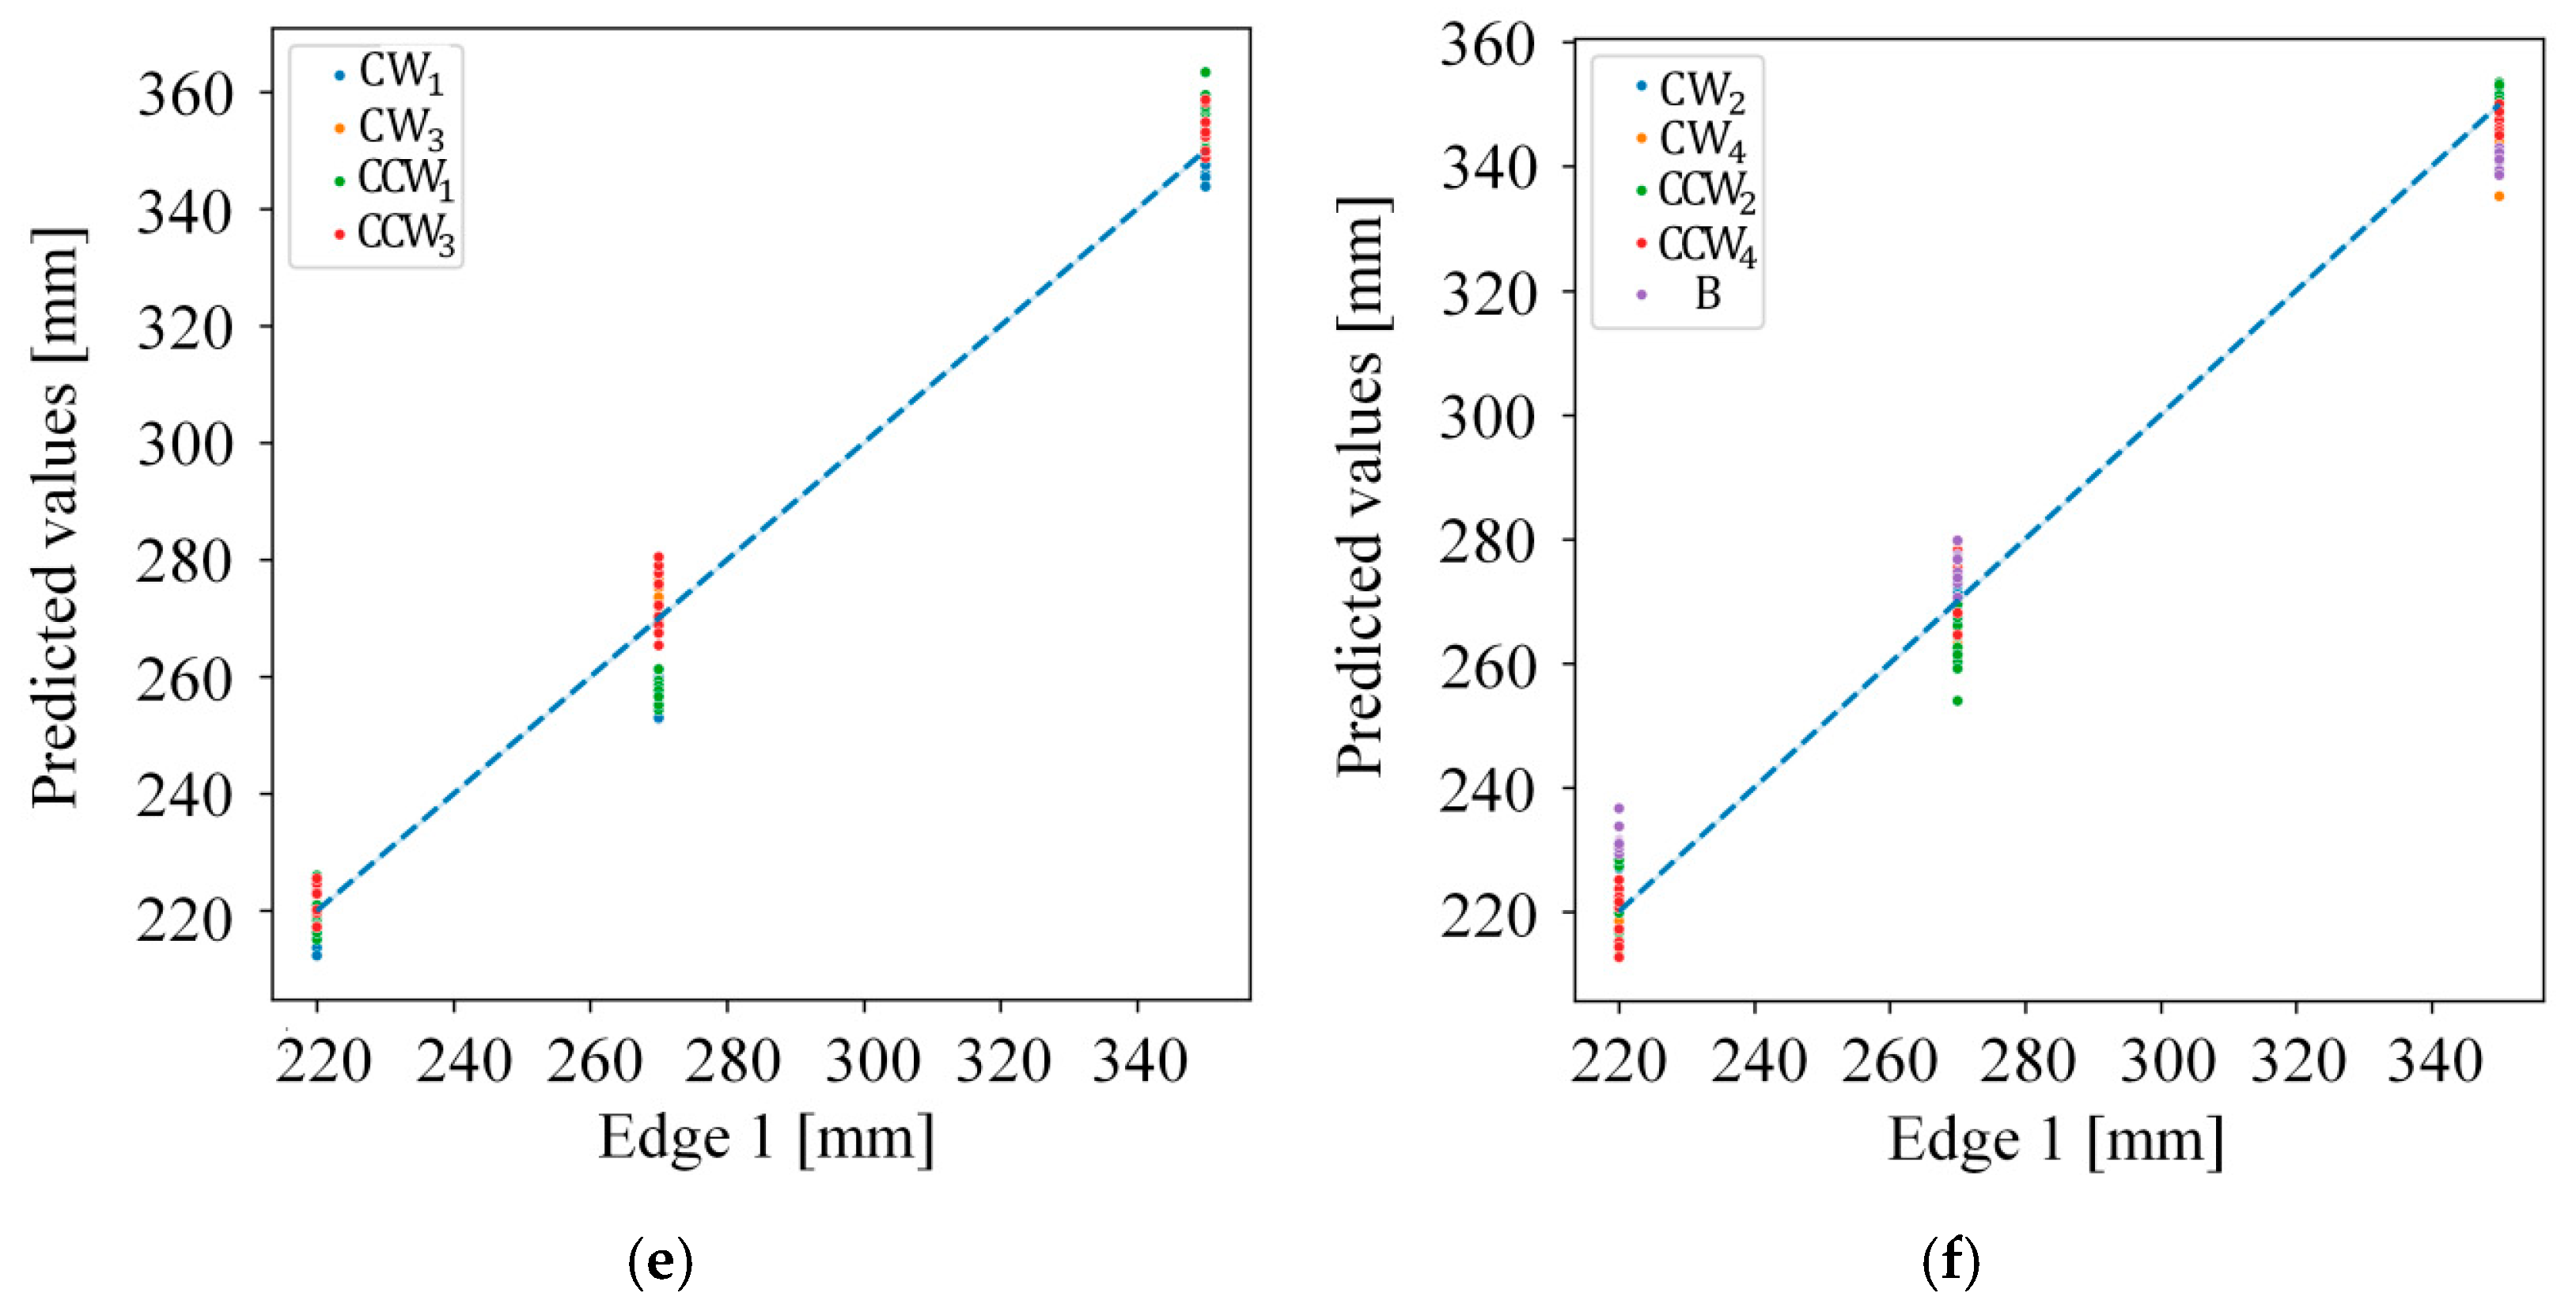
| Experiments | Model | Edge 1 [mm] | Edge 2 [mm] | ||
|---|---|---|---|---|---|
| MAE | SDE | MAE | SDE | ||
| Experiment 1 | ANN | 12.72 | 17.14 | 13.86 | 12.68 |
| RF | 15.21 | 23.79 | 16.91 | 21.25 | |
| SVR | 13.72 | 17.08 | 19.78 | 19.04 | |
| Experiment 2 | ANN | 5.83 | 5.76 | 20.28 | 17.39 |
| RF | 37.82 | 34.86 | 16.47 | 19.42 | |
| SVR | 16.90 | 17.86 | 15.85 | 16.09 | |
| Experiment 3 | ANN | 9.00 | 8.56 | 8.10 | 9.39 |
| RF | 16.14 | 15.97 | 6.28 | 7.14 | |
| SVR | 9.23 | 10.67 | 8.50 | 9.87 | |
| Experiment 4 | ANN | 9.08 | 7.04 | 9.62 | 11.81 |
| RF | 22.95 | 28.27 | 11.80 | 16.17 | |
| SVR | 16.60 | 21.19 | 8.47 | 11.73 | |
| Experiment 5 | ANN | 5.06 | 6.58 | 8.36 | 8.22 |
| RF | 10.22 | 14.79 | 4.84 | 5.99 | |
| SVR | 9.72 | 11.59 | 7.24 | 9.94 | |
| Experiment 6 | ANN | 5.38 | 6.47 | 7.60 | 8.21 |
| RF | 13.93 | 21.28 | 7.71 | 12.98 | |
| SVR | 8.84 | 10.59 | 6.93 | 9.87 | |
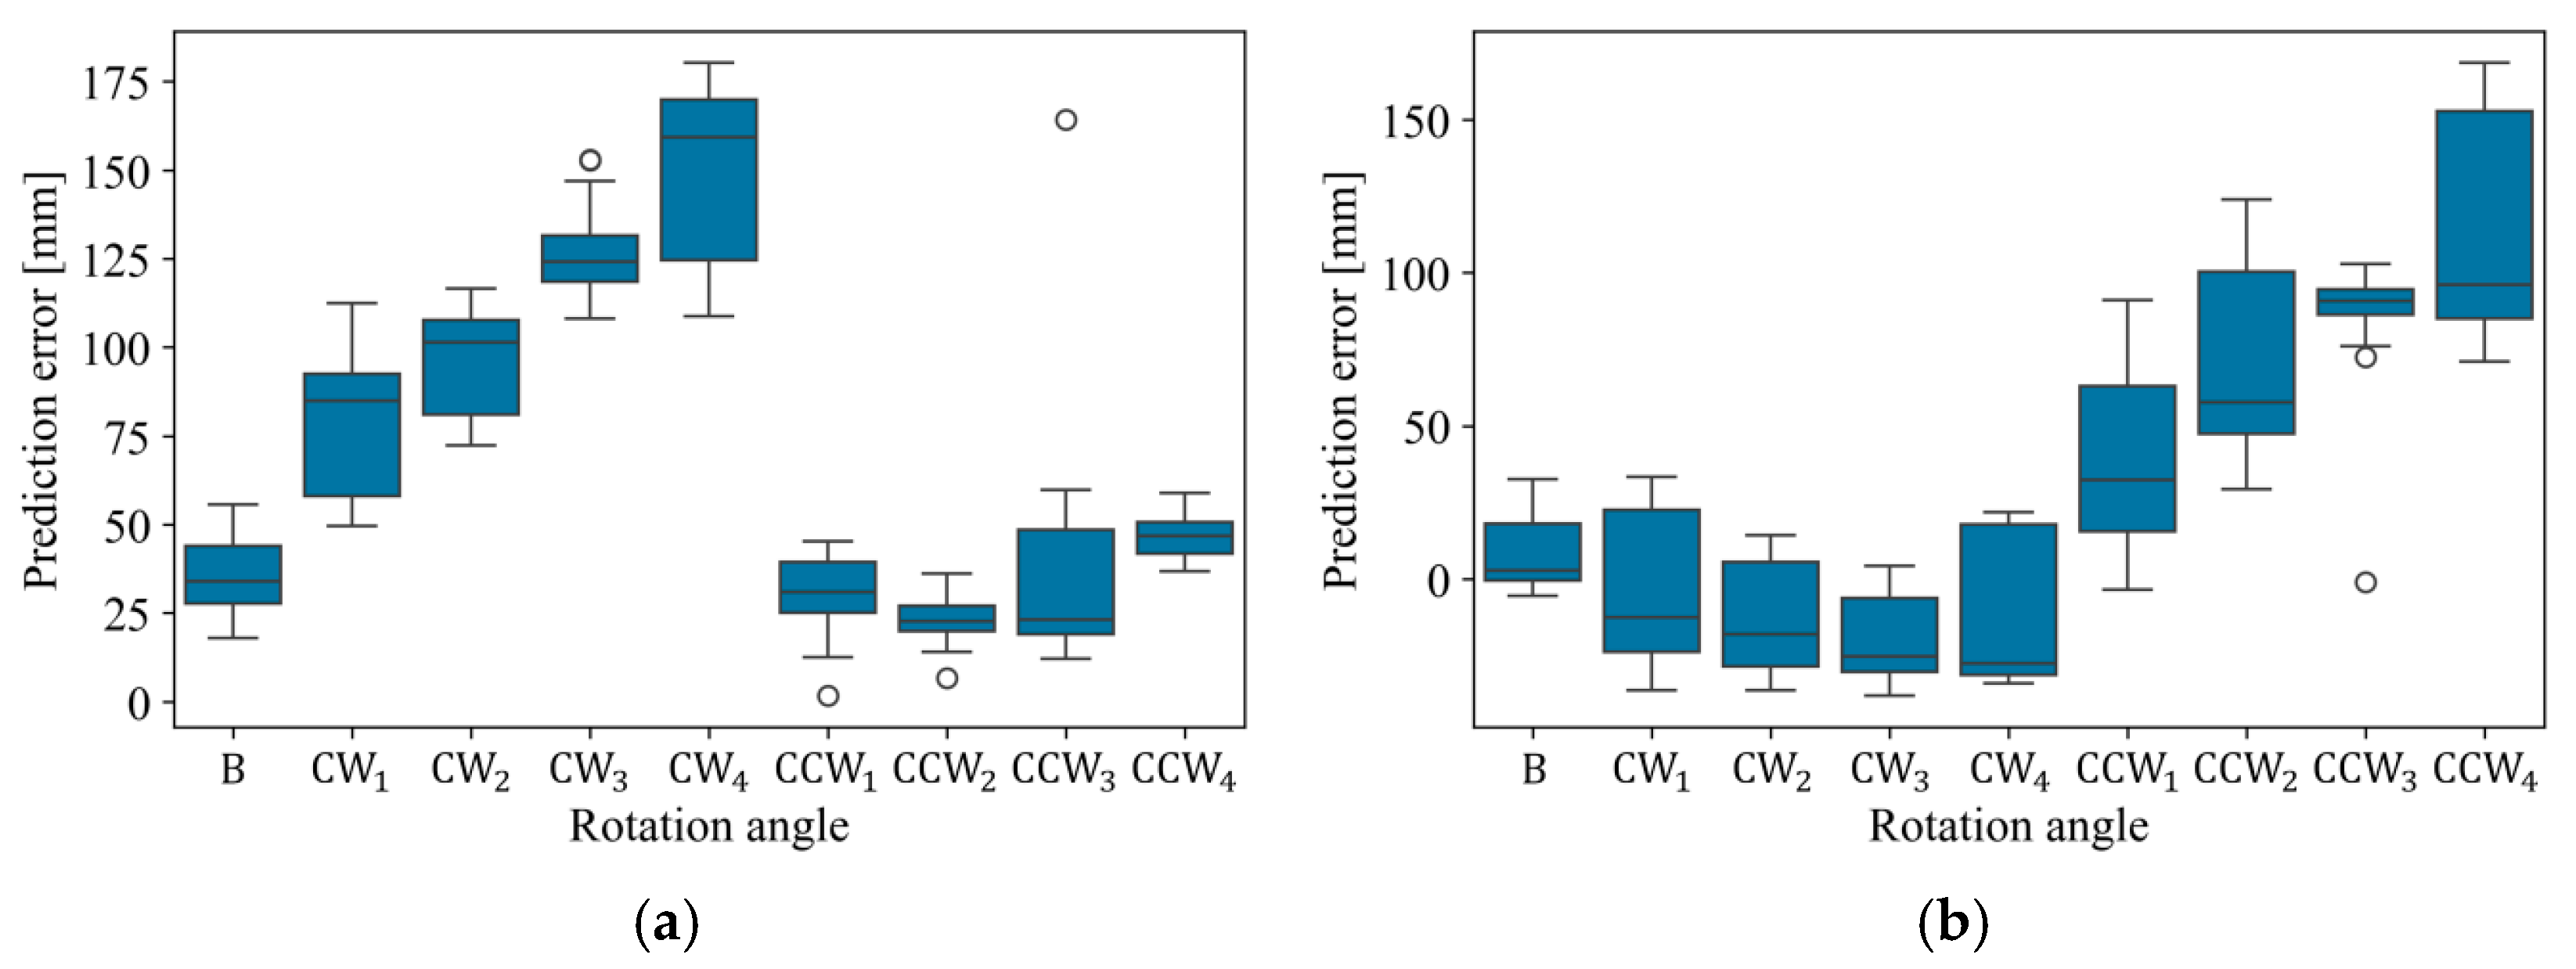
| Model | Edge 1 [mm] | Edge 2 [mm] | ||
|---|---|---|---|---|
| MAE | SDE | MAE | SDE | |
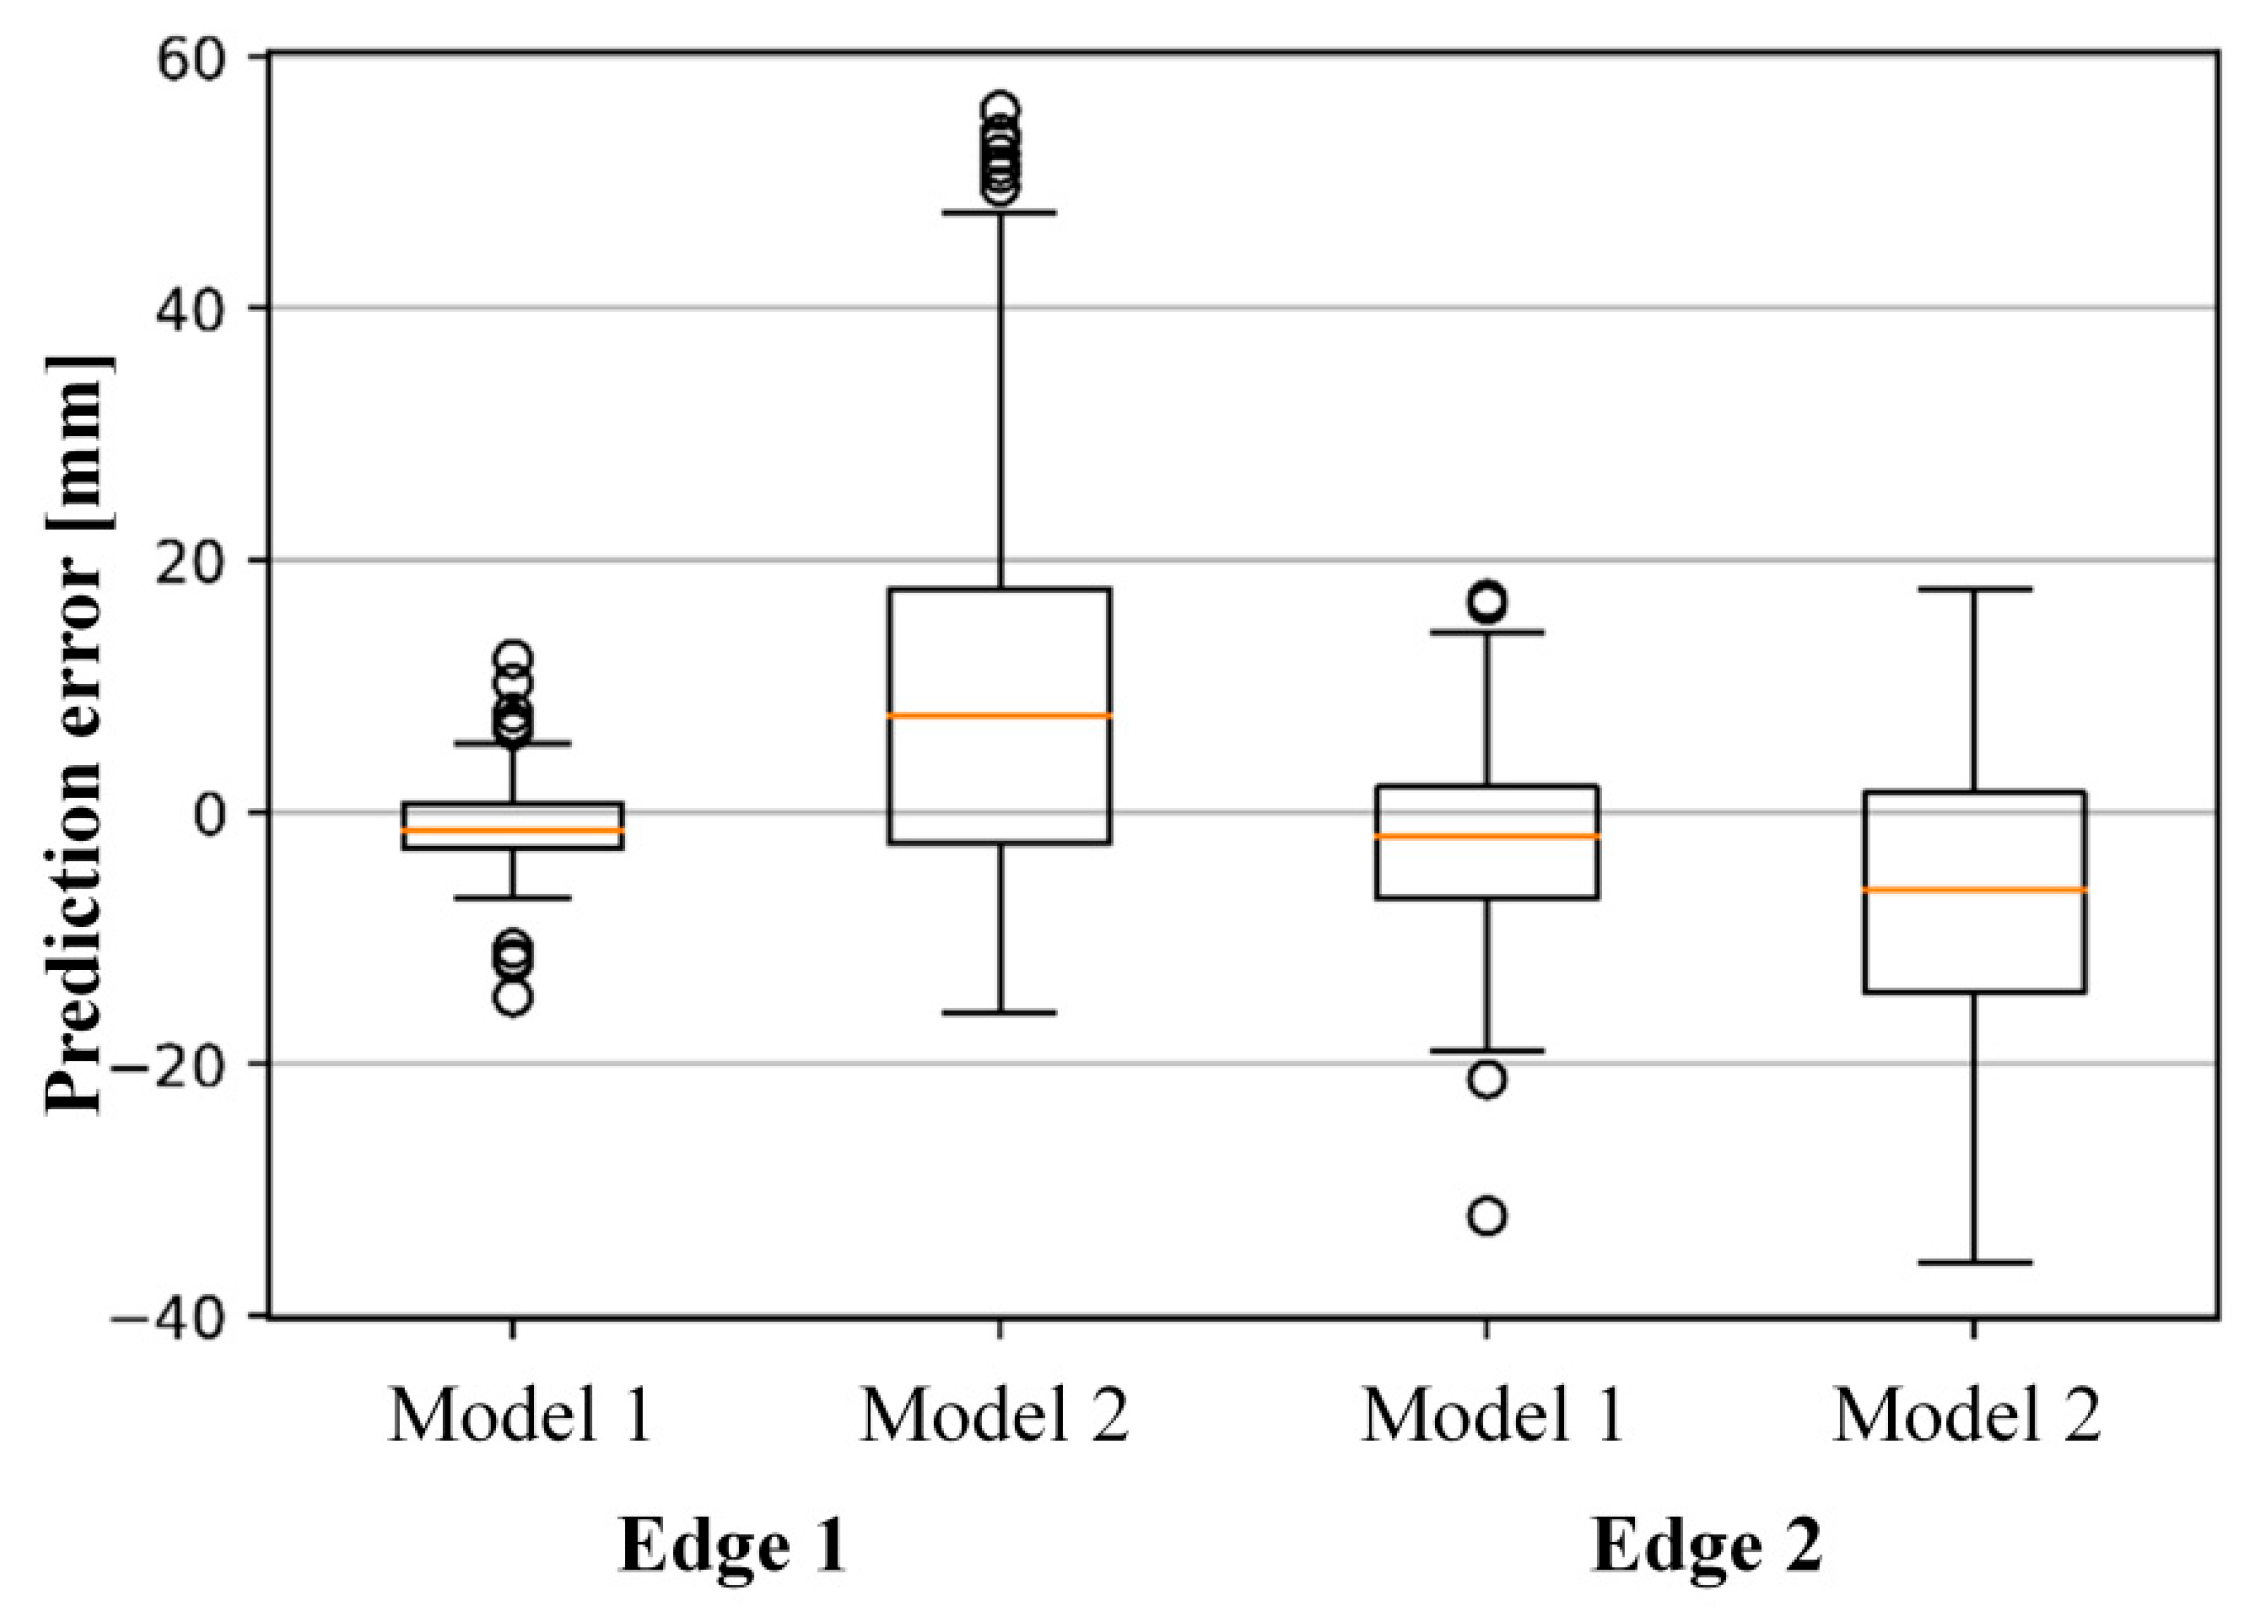
| Model 1 | 2.88 | 2.57 | 6.03 | 5.24 |
| Model 2 | 15.84 | 15.41 | 11.46 | 8.12 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Heo, H.B.; Park, S.H. Artificial Neural Network-Based Conveying Object Measurement Automation System Using Distance Sensor. Sensors 2026, 26, 455. https://doi.org/10.3390/s26020455
Heo HB, Park SH. Artificial Neural Network-Based Conveying Object Measurement Automation System Using Distance Sensor. Sensors. 2026; 26(2):455. https://doi.org/10.3390/s26020455
Chicago/Turabian StyleHeo, Hyo Beom, and Seung Hwan Park. 2026. "Artificial Neural Network-Based Conveying Object Measurement Automation System Using Distance Sensor" Sensors 26, no. 2: 455. https://doi.org/10.3390/s26020455
APA StyleHeo, H. B., & Park, S. H. (2026). Artificial Neural Network-Based Conveying Object Measurement Automation System Using Distance Sensor. Sensors, 26(2), 455. https://doi.org/10.3390/s26020455