
PDR Combined with Magnetic Fingerprint Algorithm for Indoor Positioning †


Abstract
1. Introduction
1.1. Motivation
1.2. Problem Statement
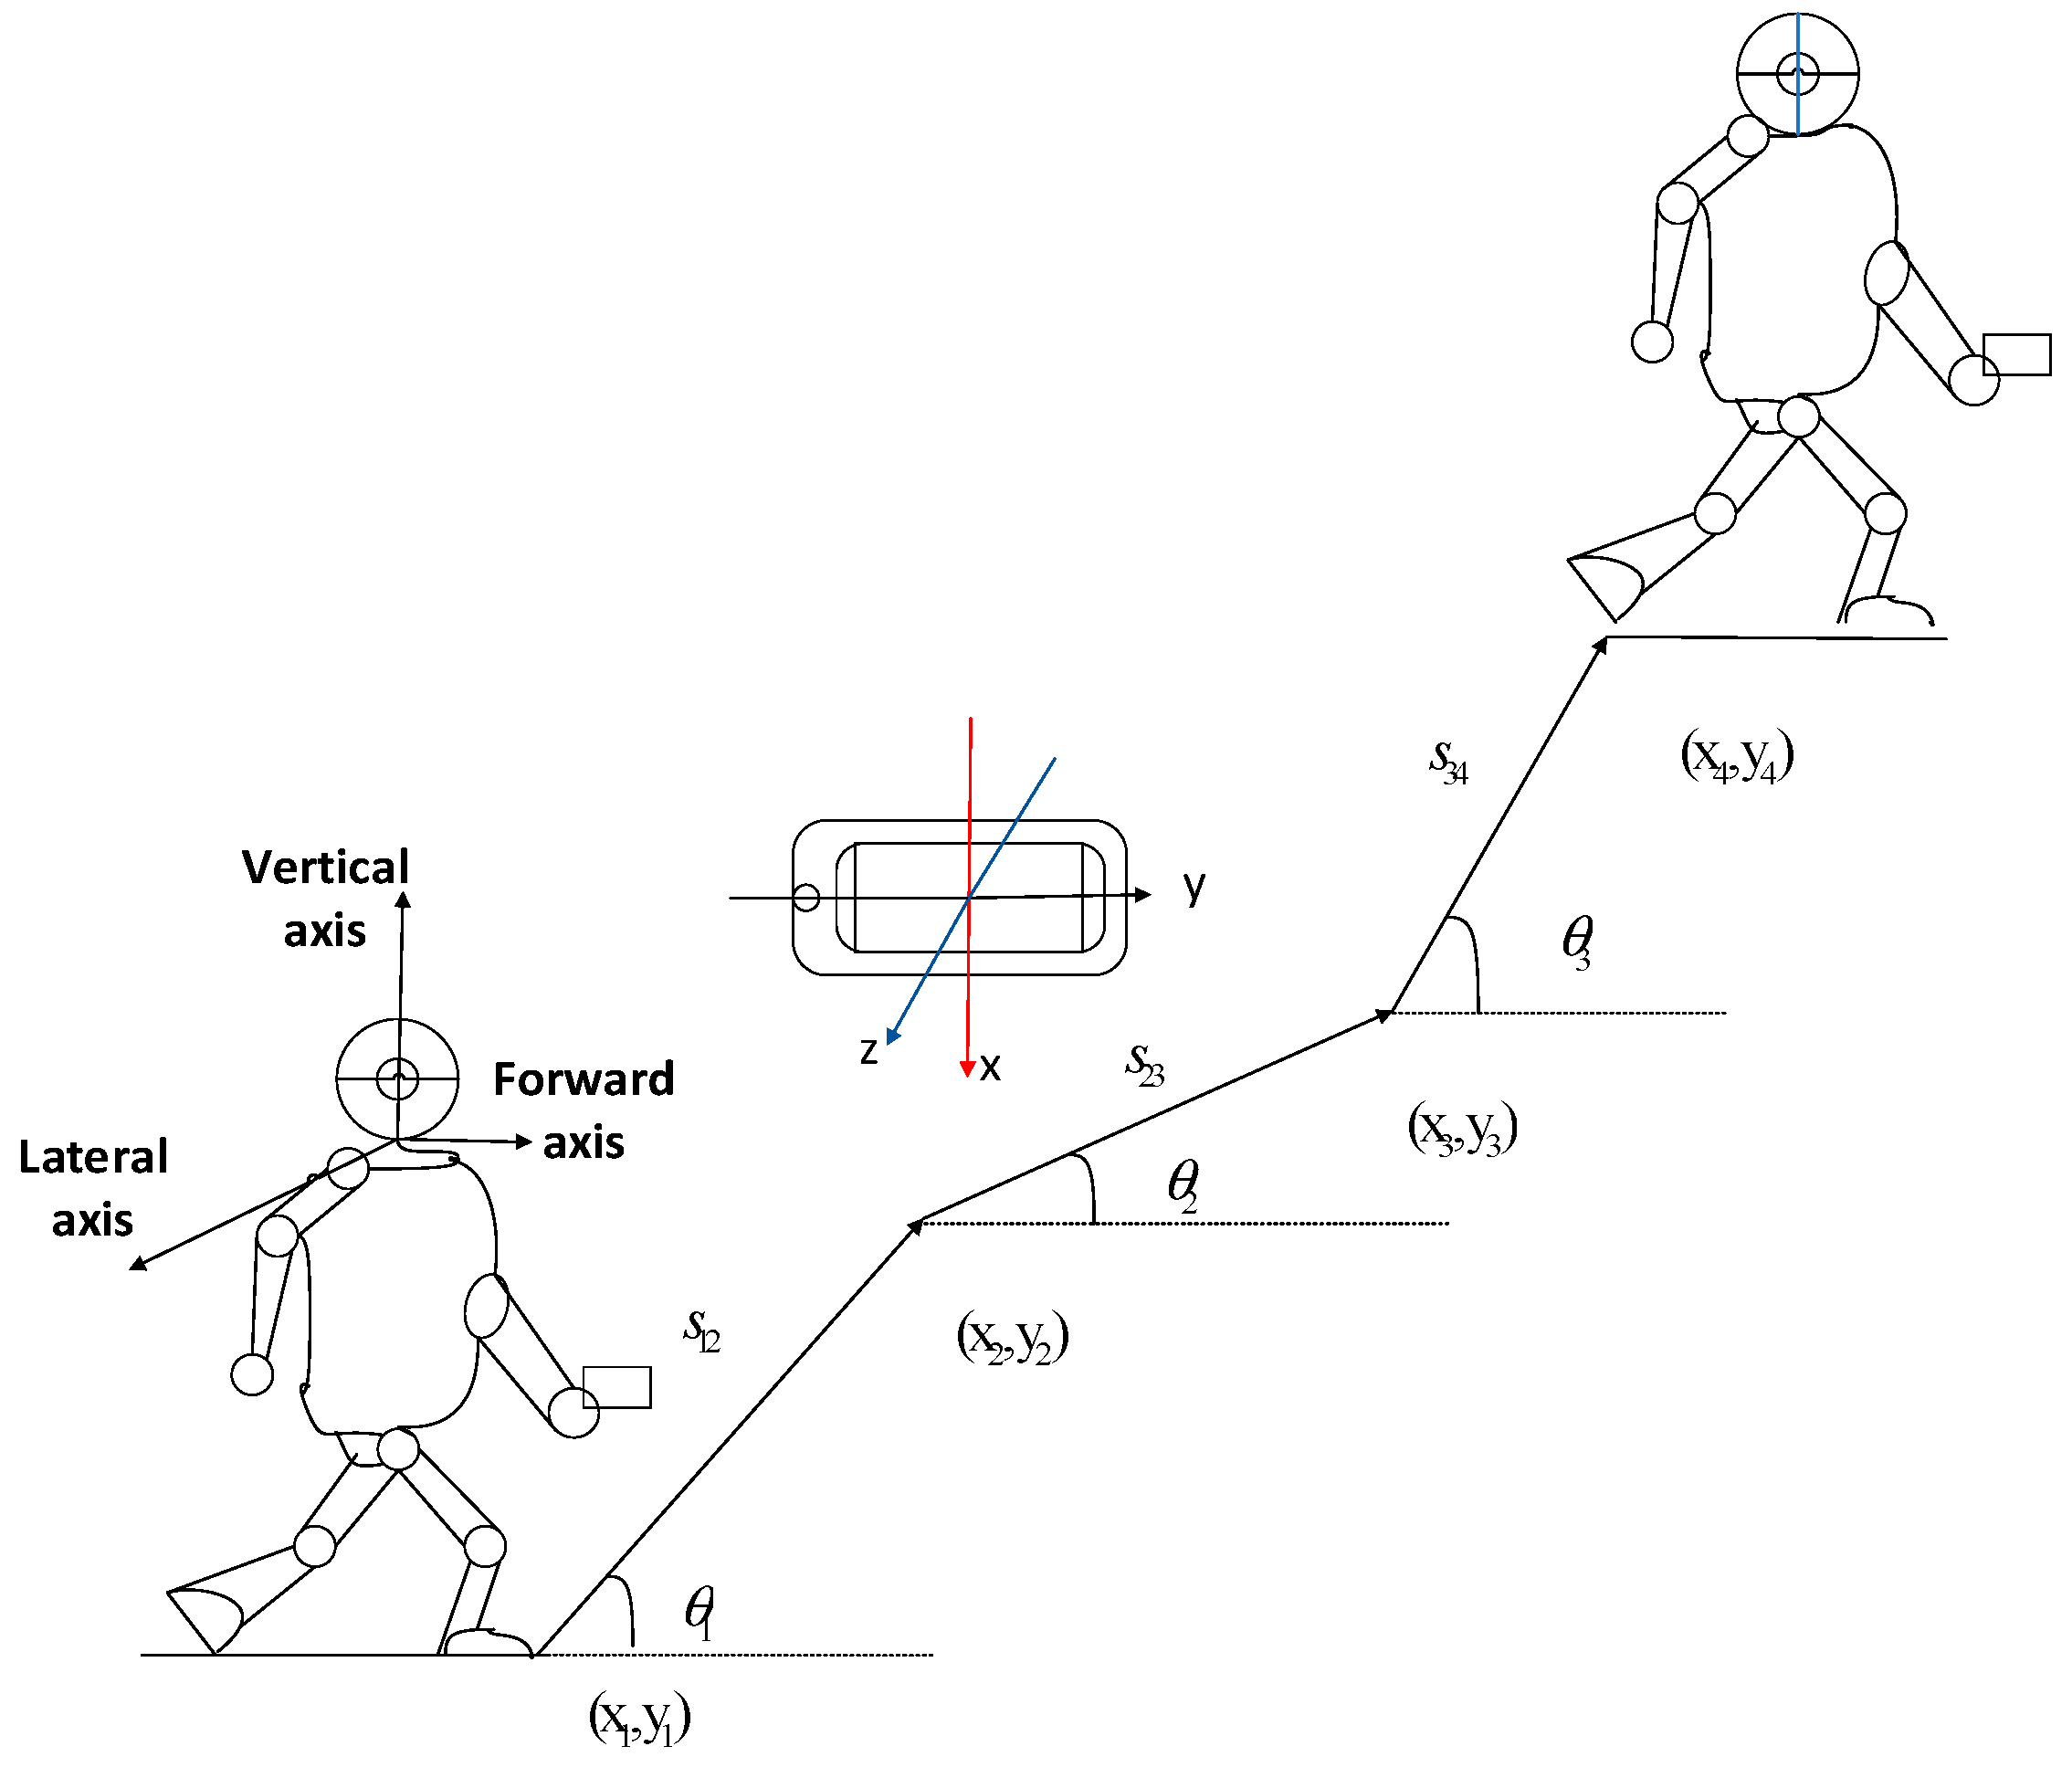
2. PDR Positioning Algorithm
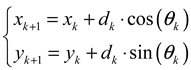
3. Fusion Location Algorithm
3.1. Particle Filter Algorithm
 to approximate the posterior density function. The formula is derived as follows
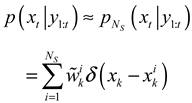
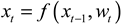
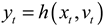
- 1.
- randomly generate a sample from the uniformly distributed [0, 1] interval ut~U [0, 1], t= 1, 2, …, n;
- 2.
- Set the particle set (
 ) corresponding to the particle index i satisfying Formula (5) as the t-th particle (
 ) in the new particle set;

- 3.
- Repeat n times to generate a new set of particles, each with a weight of 1/n.


3.2. GPDR (Geomagnetic + PDR Algorithm) Based on Particle Filter Algorithm Fusion
- Initialize.
- Particle state transfer.
- Weight calculation.
- Location update. Updated pedestrian position (xk,yk), calculated as follows:

- Resample. If
 less than the preset threshold, enter the resampling phase. Get the final positioning result of the system.
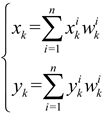

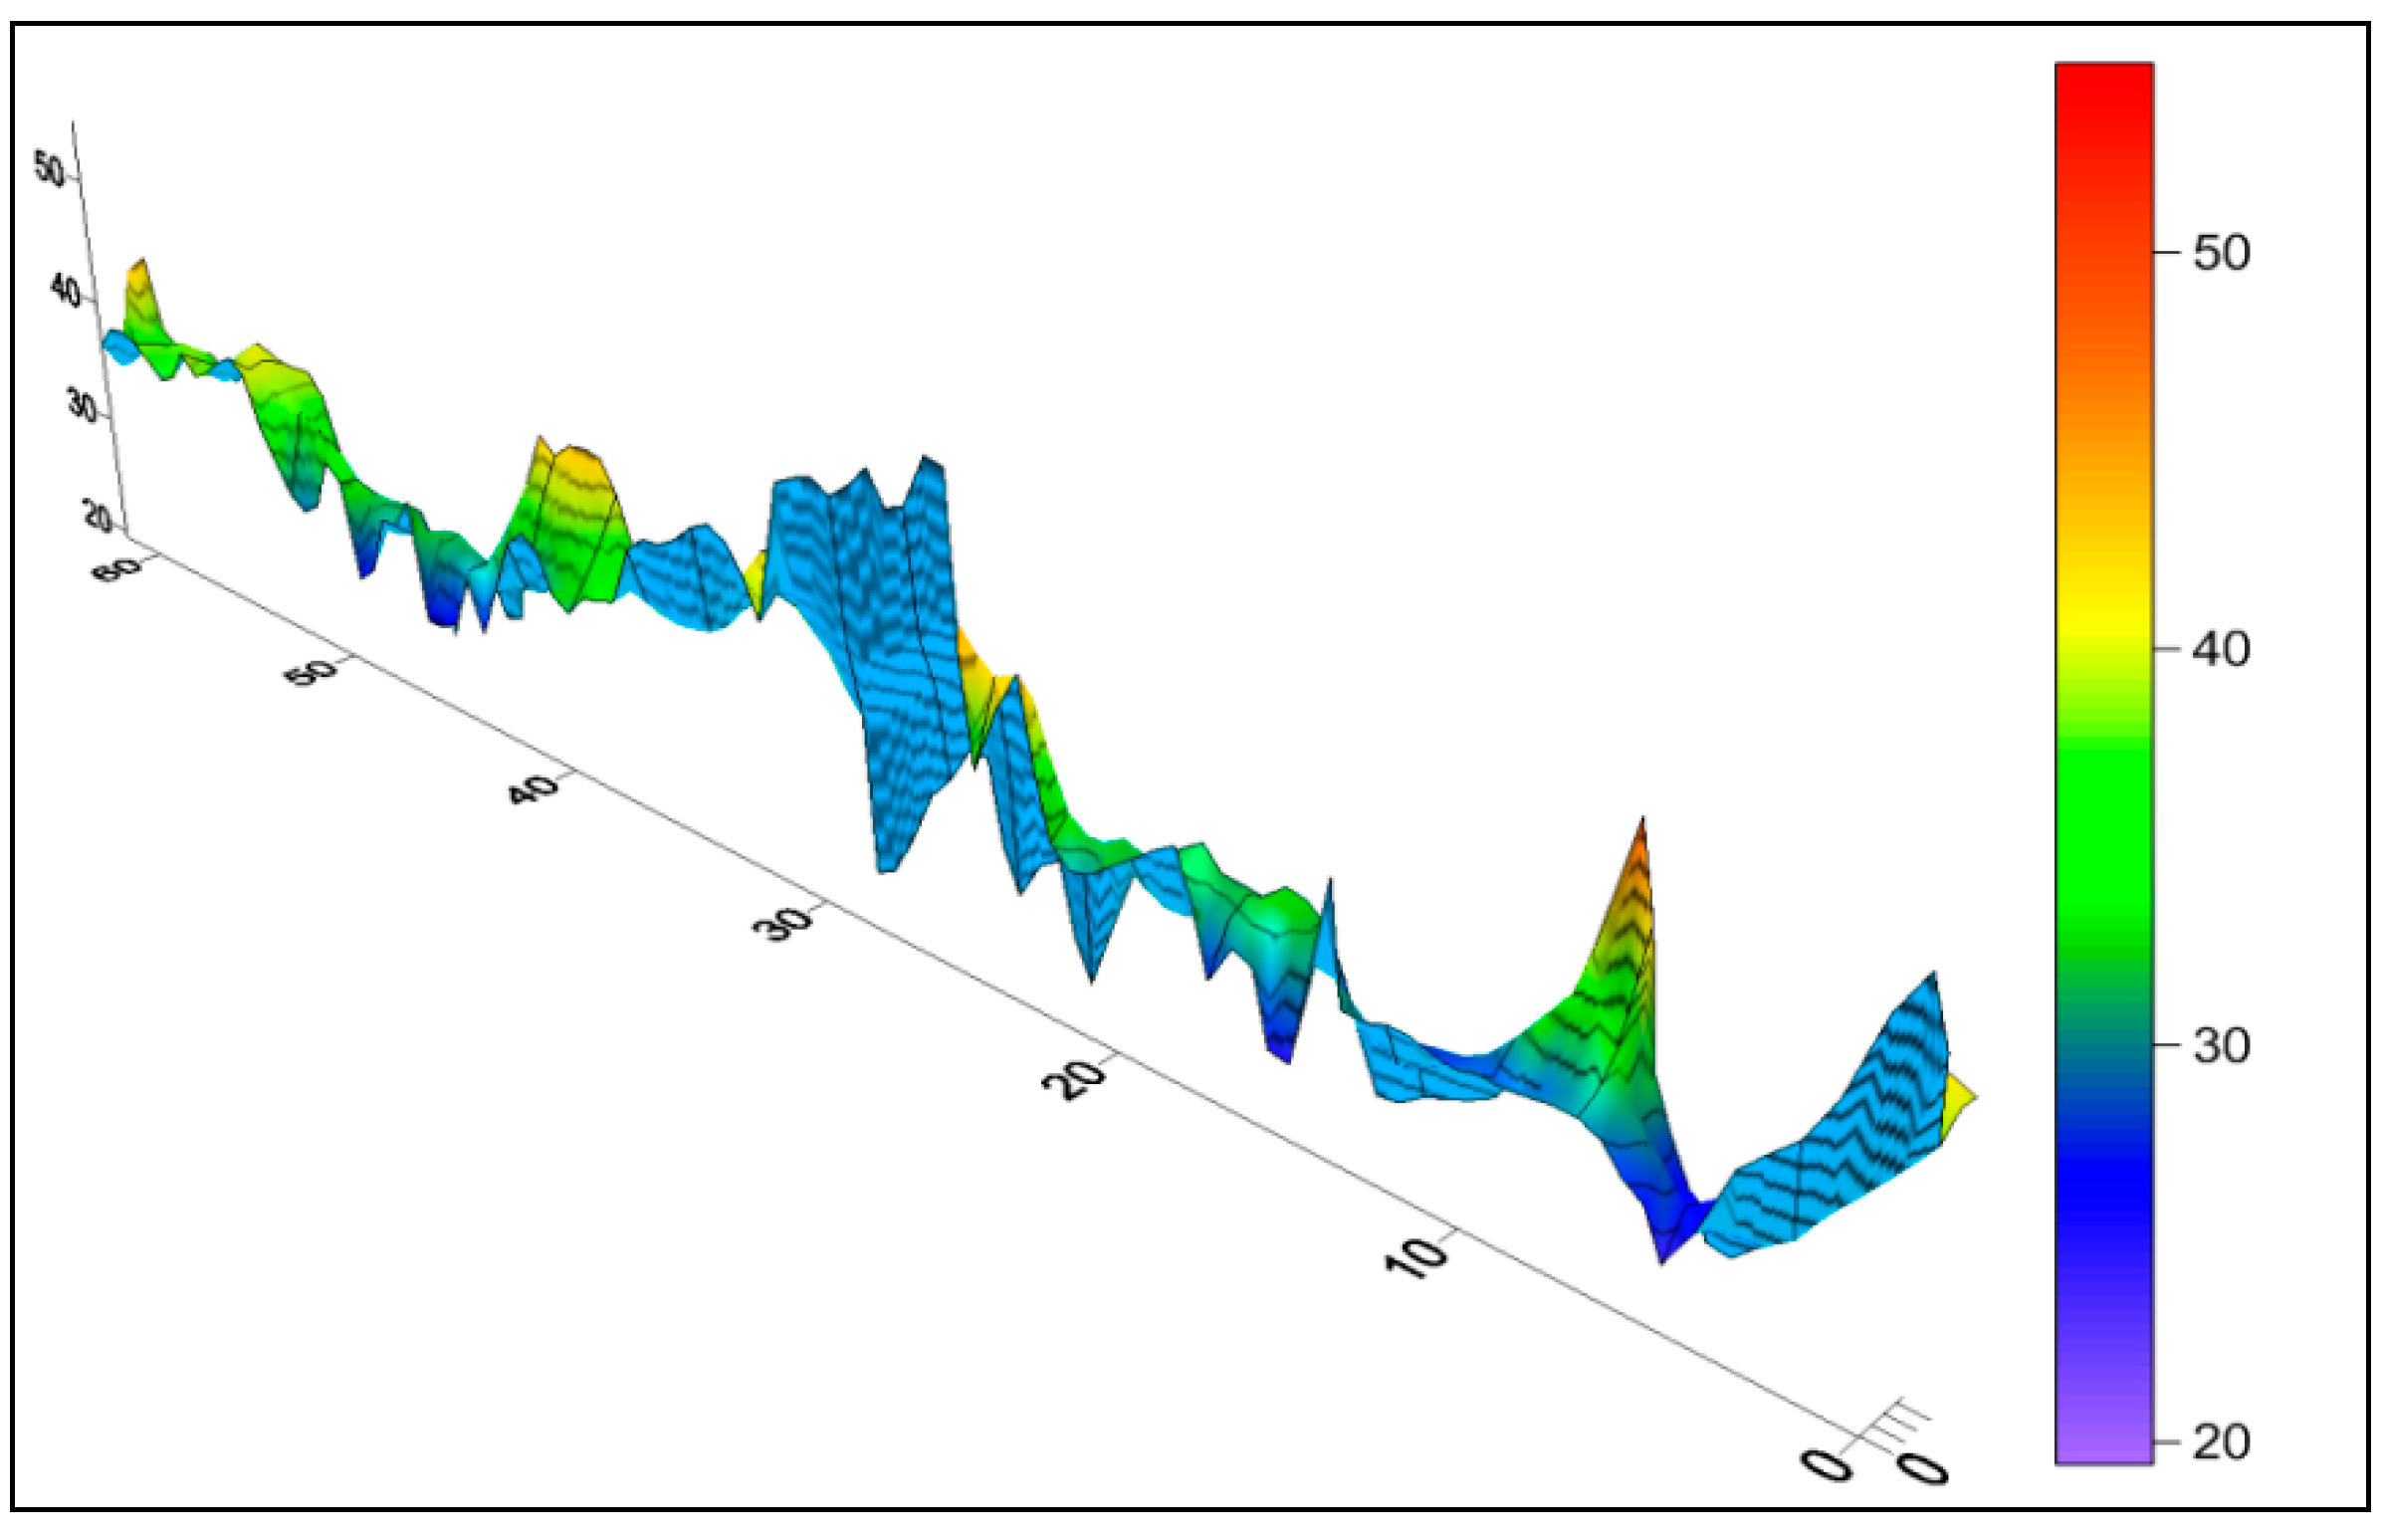
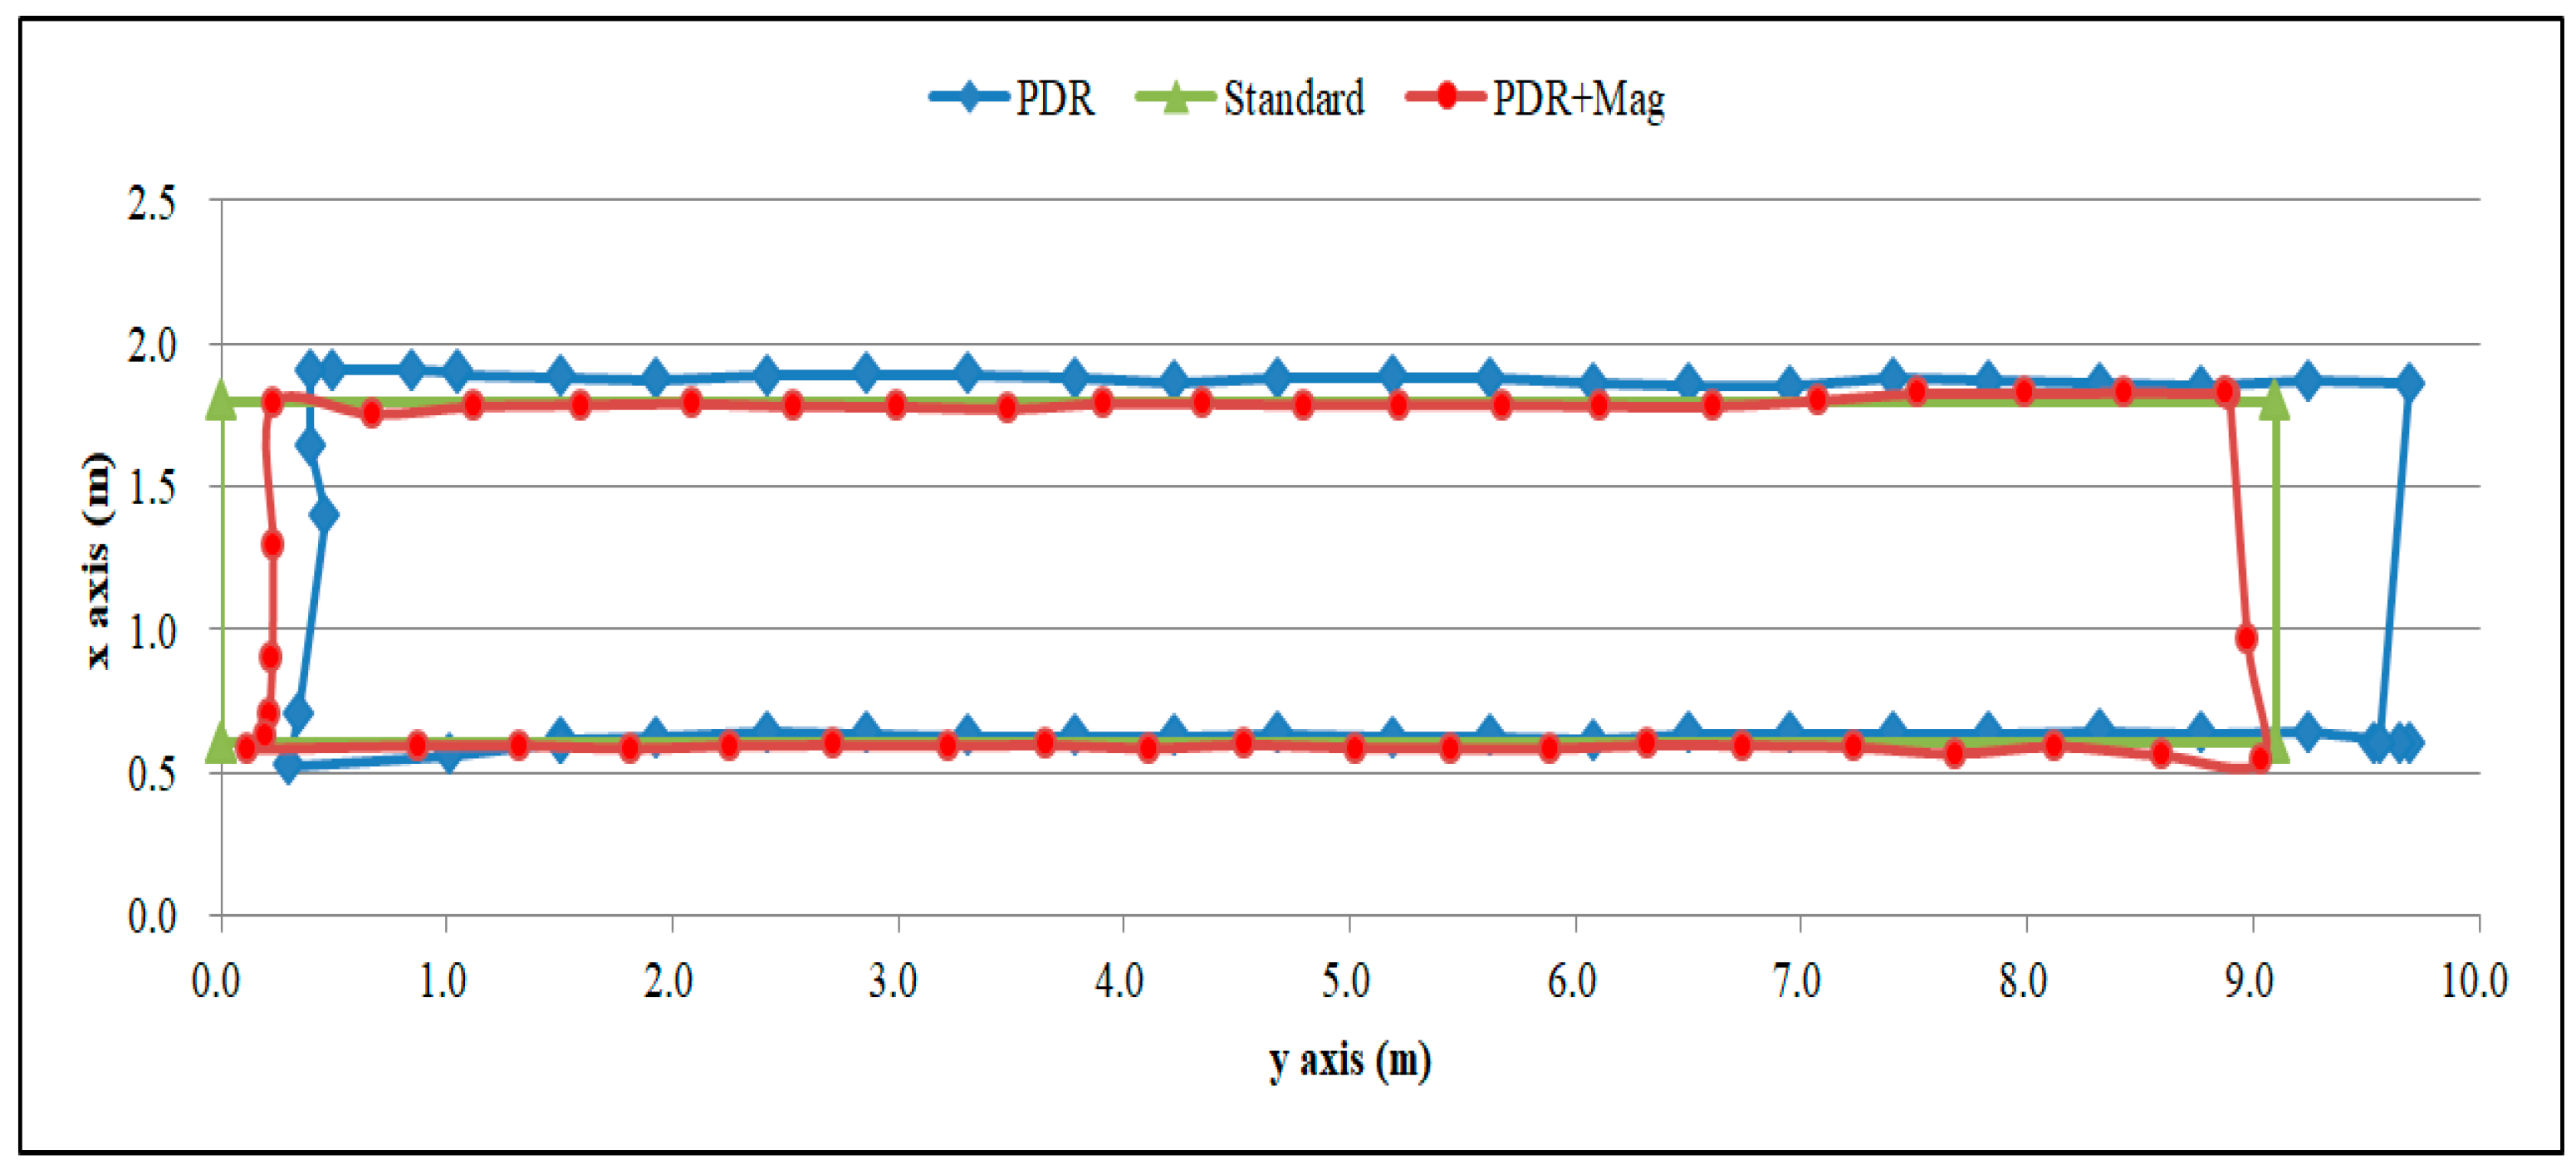
4. Experimental Results and Analysis
5. Conclusions
References
- Angermann, M.; Frassl, M.; Doniec, M.; Julian, B.J.; Robertson, P. Characterization of the indoor magnetic field for applications in Localization and Mapping. In Proceedings of the International Conference on Indoor Positioning and Indoor Navigation, Sydney, Australia, 13–15 November 2013; pp. 1–9. [Google Scholar]
- Zou, Y.; Wang, G.; Wu, K.; Ni, L.M. SmartScanner: Know more in walls with your smartphone. IEEE Trans. Mob. Comput. 2016, 15, 2865–2877. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.; Subbu, K.P.; Luo, J.; Wu, J. GROPING: Geomagnetism and crowd sensing powered indoor navigation. IEEE Trans. Mob. Comput. 2015, 14, 387–400. [Google Scholar] [CrossRef] [Scilit]
- Li, B. Using Geomagnetic Field for Indoor Positioning. J. Appl. Geod. 2013, 7, 299–308. [Google Scholar] [CrossRef] [Scilit]
- Jimenez, A.R.; Seco, F.; Prieto, C.; Guevara, J. A comparison of Pedestrian Dead-Reckoning algorithms using a low-cost MEMS IMU. In Proceedings of the IEEE International Symposium on Intelligent Signal Processing (WISP’09), Budapest, Hungary, 26–28 August 2009; pp. 37–42. [Google Scholar]
- Elvira, V.; Miguez, J.; Djuric, P.M. Adapting the Number of Particles in Sequential Monte Carlo Methods through an Online Scheme for Convergence Assessment. IEEE Trans. Signal Process. 2017, 65, 1781–1794. [Google Scholar] [CrossRef] [Scilit]
- Gordon, N.; Salmond, D.; Smith, A.F.M. Novel approach to nonlinear and non-Gaussian Bayesian state estimation. Proc. Inst. Elect. Eng. F 1993, 140, 107–113. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2018 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).
Share and Cite
Huang, H.; Qiu, K.; Li, W.; Luo, D. PDR Combined with Magnetic Fingerprint Algorithm for Indoor Positioning. Proceedings 2019, 4, 24. https://doi.org/10.3390/ecsa-5-05726
Huang H, Qiu K, Li W, Luo D. PDR Combined with Magnetic Fingerprint Algorithm for Indoor Positioning. Proceedings. 2019; 4(1):24. https://doi.org/10.3390/ecsa-5-05726
Chicago/Turabian StyleHuang, He, Kaiyue Qiu, Wei Li, and Dean Luo. 2019. "PDR Combined with Magnetic Fingerprint Algorithm for Indoor Positioning" Proceedings 4, no. 1: 24. https://doi.org/10.3390/ecsa-5-05726
APA StyleHuang, H., Qiu, K., Li, W., & Luo, D. (2019). PDR Combined with Magnetic Fingerprint Algorithm for Indoor Positioning. Proceedings, 4(1), 24. https://doi.org/10.3390/ecsa-5-05726


