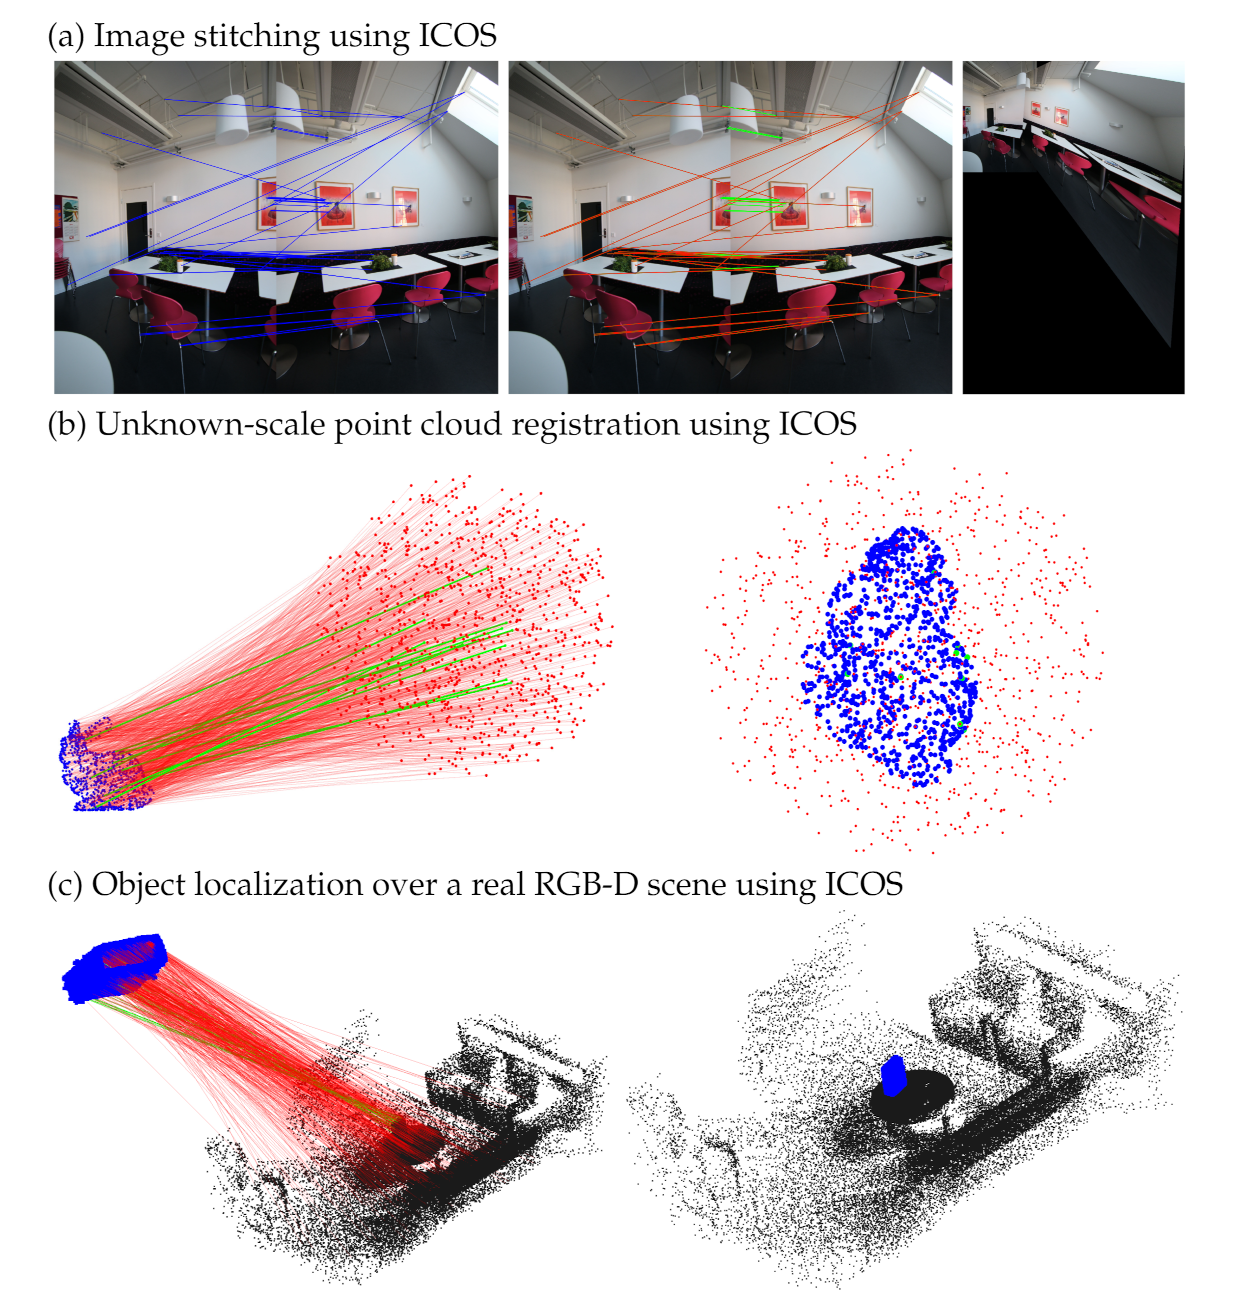
A Fast and Robust Rotation Search and Point Cloud Registration Method for 2D Stitching and 3D Object Localization

Abstract
1. Introduction
1.1. Problems Formulation
1.2. Motivation and Contributions
2. Related Work
3. Notation and Preliminaries
3.1. Invariants
3.2. Naive and Nonminimal Solvers
4. Compatible Structures in the Point Cloud Registration Problem
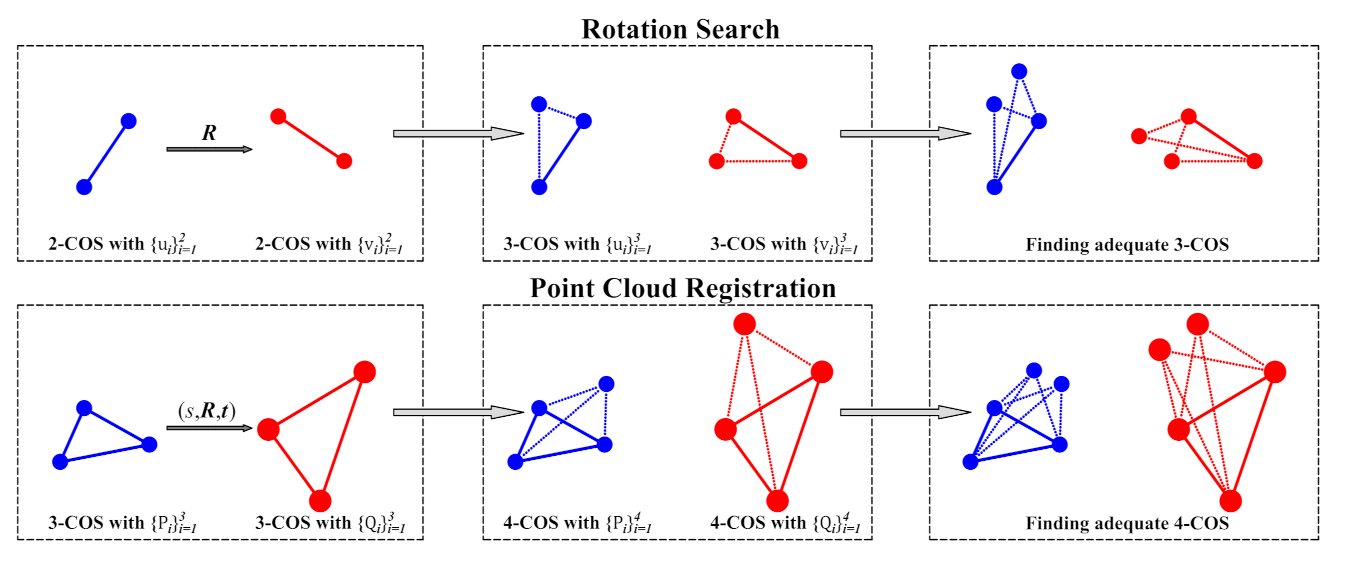
4.1. COS in Rotation Search
4.2. COS in Point Cloud Registration
5. Our Solver: ICOS
5.1. ICOS for Rotation Search
| Algorithm 1: ICOS for rotation search |
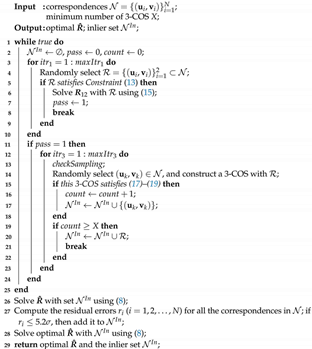 |
| Algorithm 2:checkSampling (subroutine of ICOS) |
 |
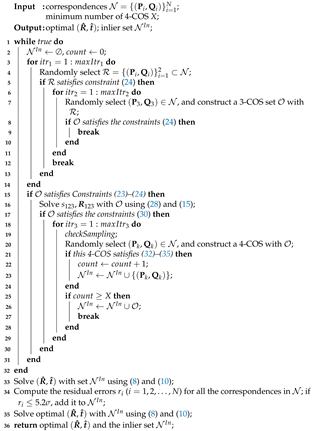
5.2. ICOS for Known-Scale Registration
5.3. ICOS for Unknown-Scale Registration
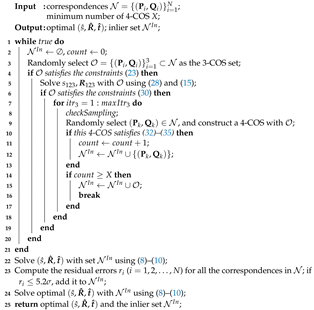
| Algorithm 4: ICOS for unknown-scale registration |
 |
5.4. Discussion on the Maximum Iteration Numbers
5.5. Discussion on the Performance of ICOS
6. Experiments
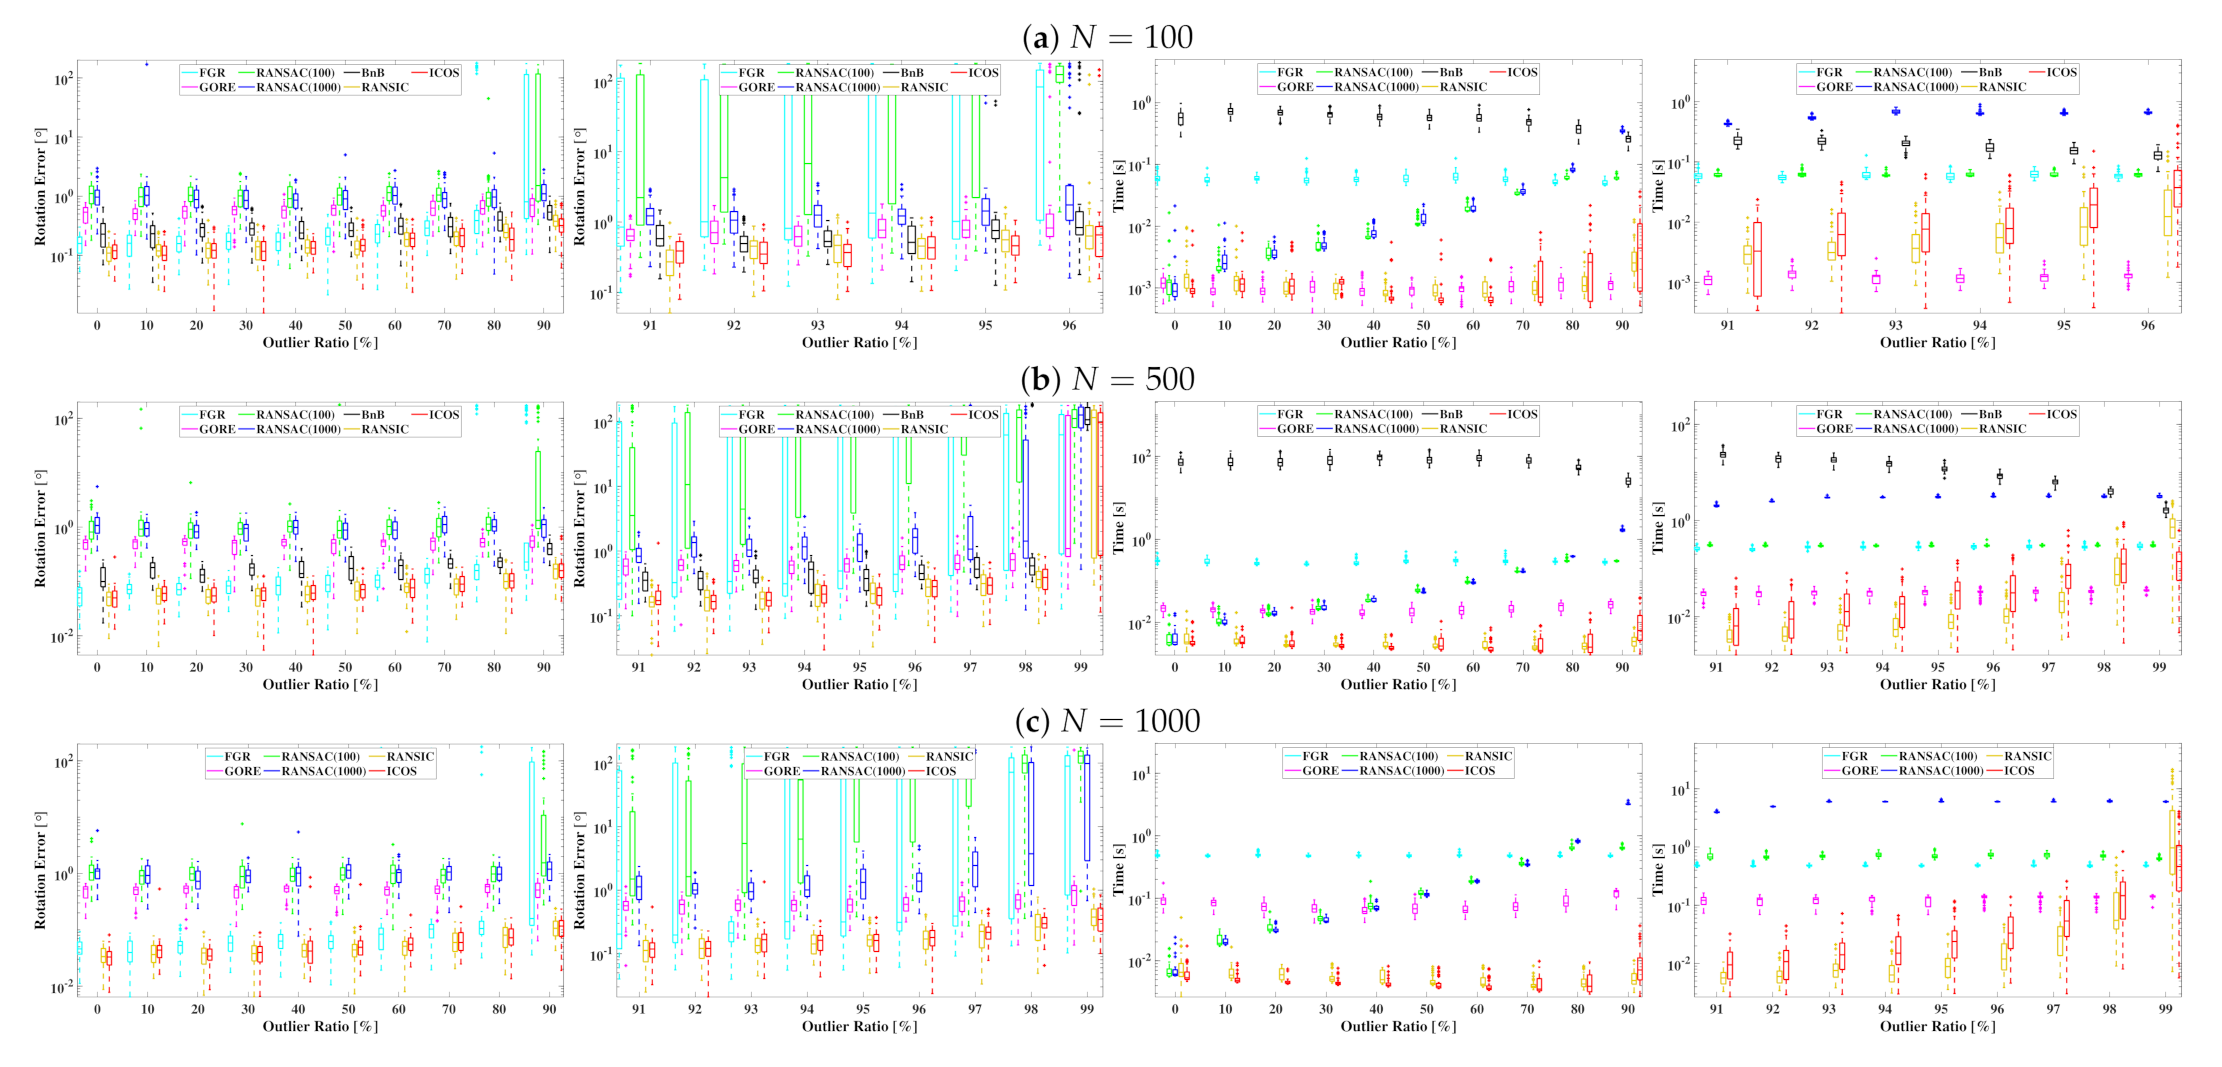
6.1. Benchmarking of Rotation Search on Synthetic Data
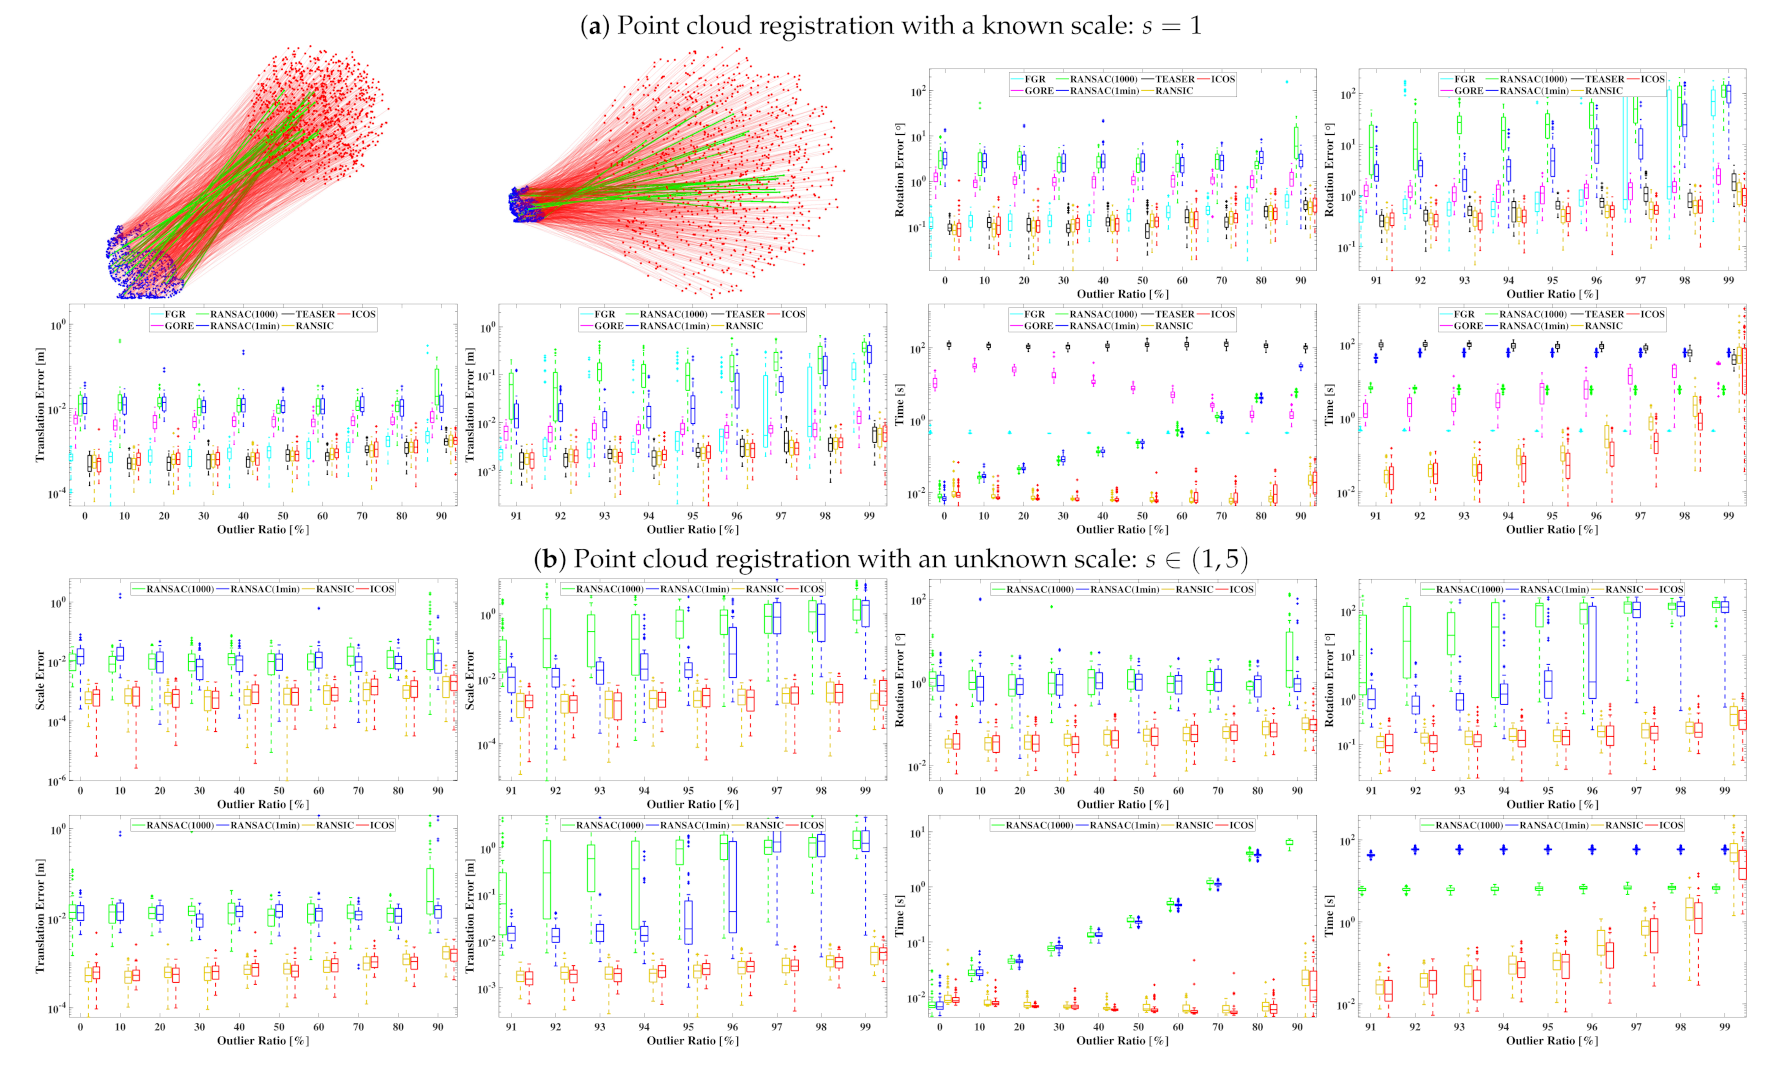
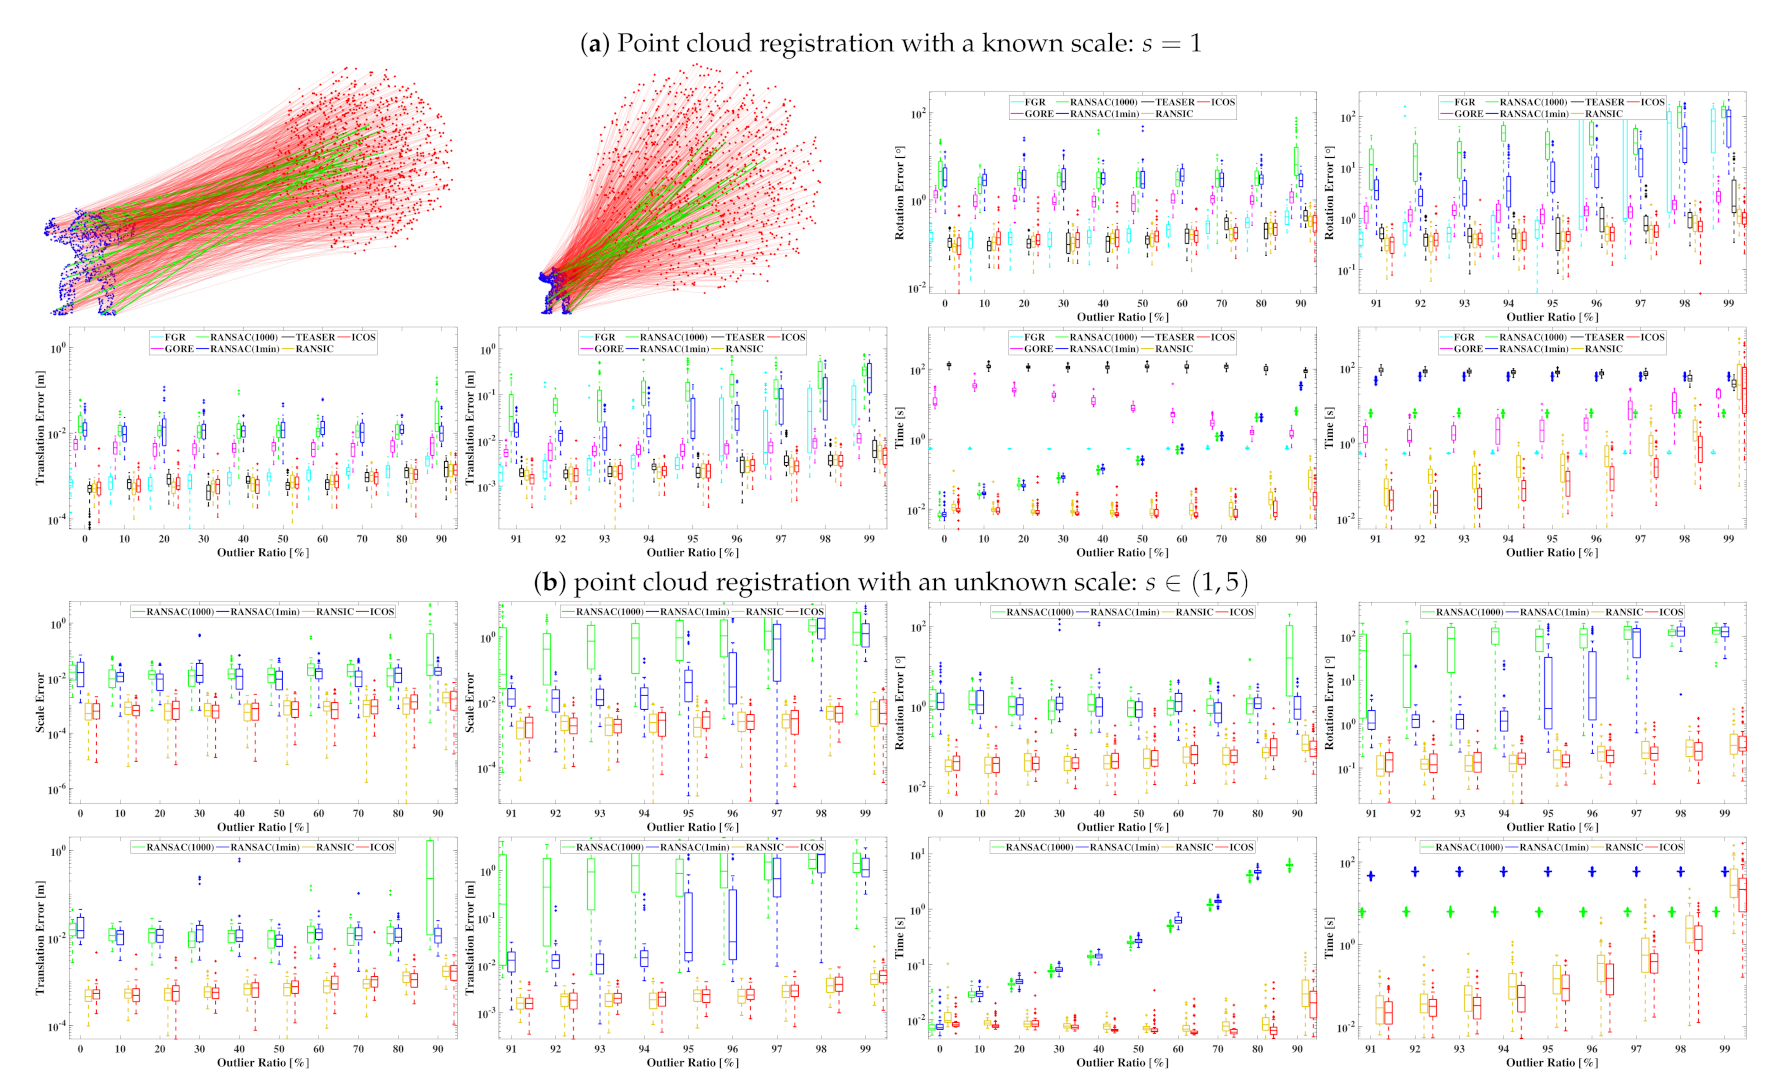
6.2. Benchmarking of Point Cloud Registration on Real Data
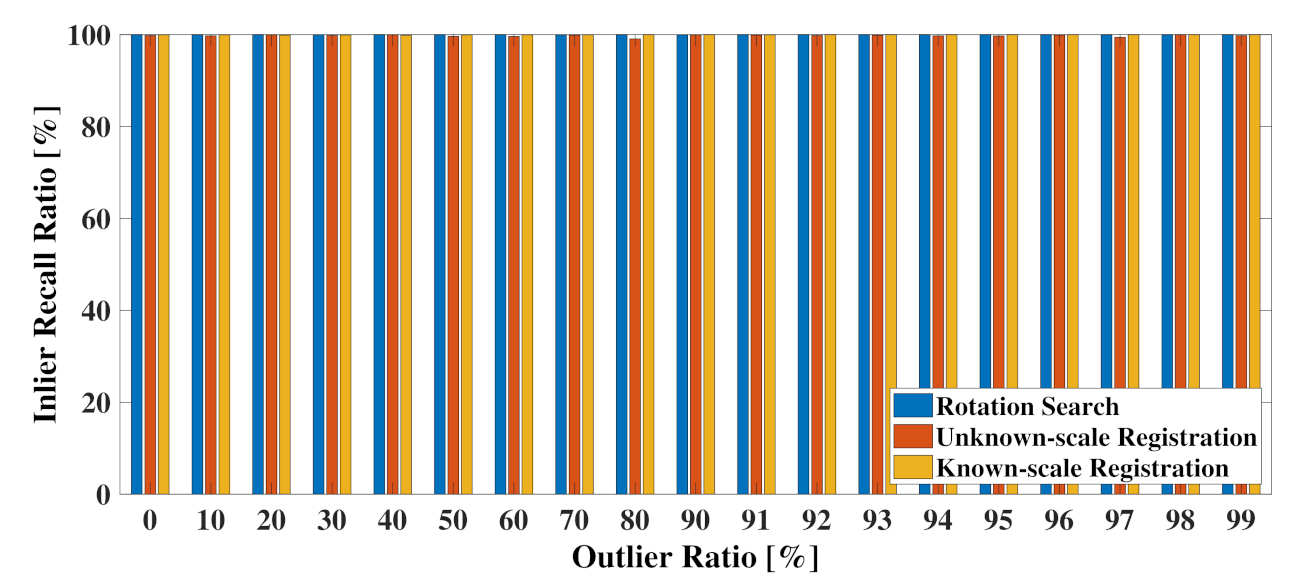
6.3. Evaluation on the Inlier Recall Ratio
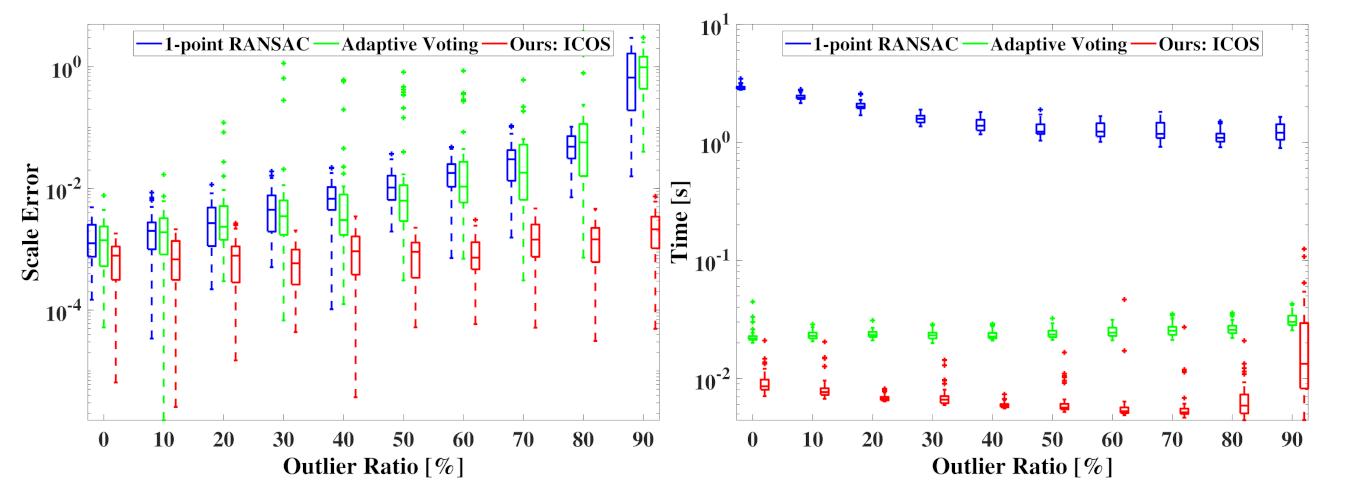
6.4. Benchmarking on Scale Estimation in Registration
6.5. Qualitative Registration Results over Real Datasets
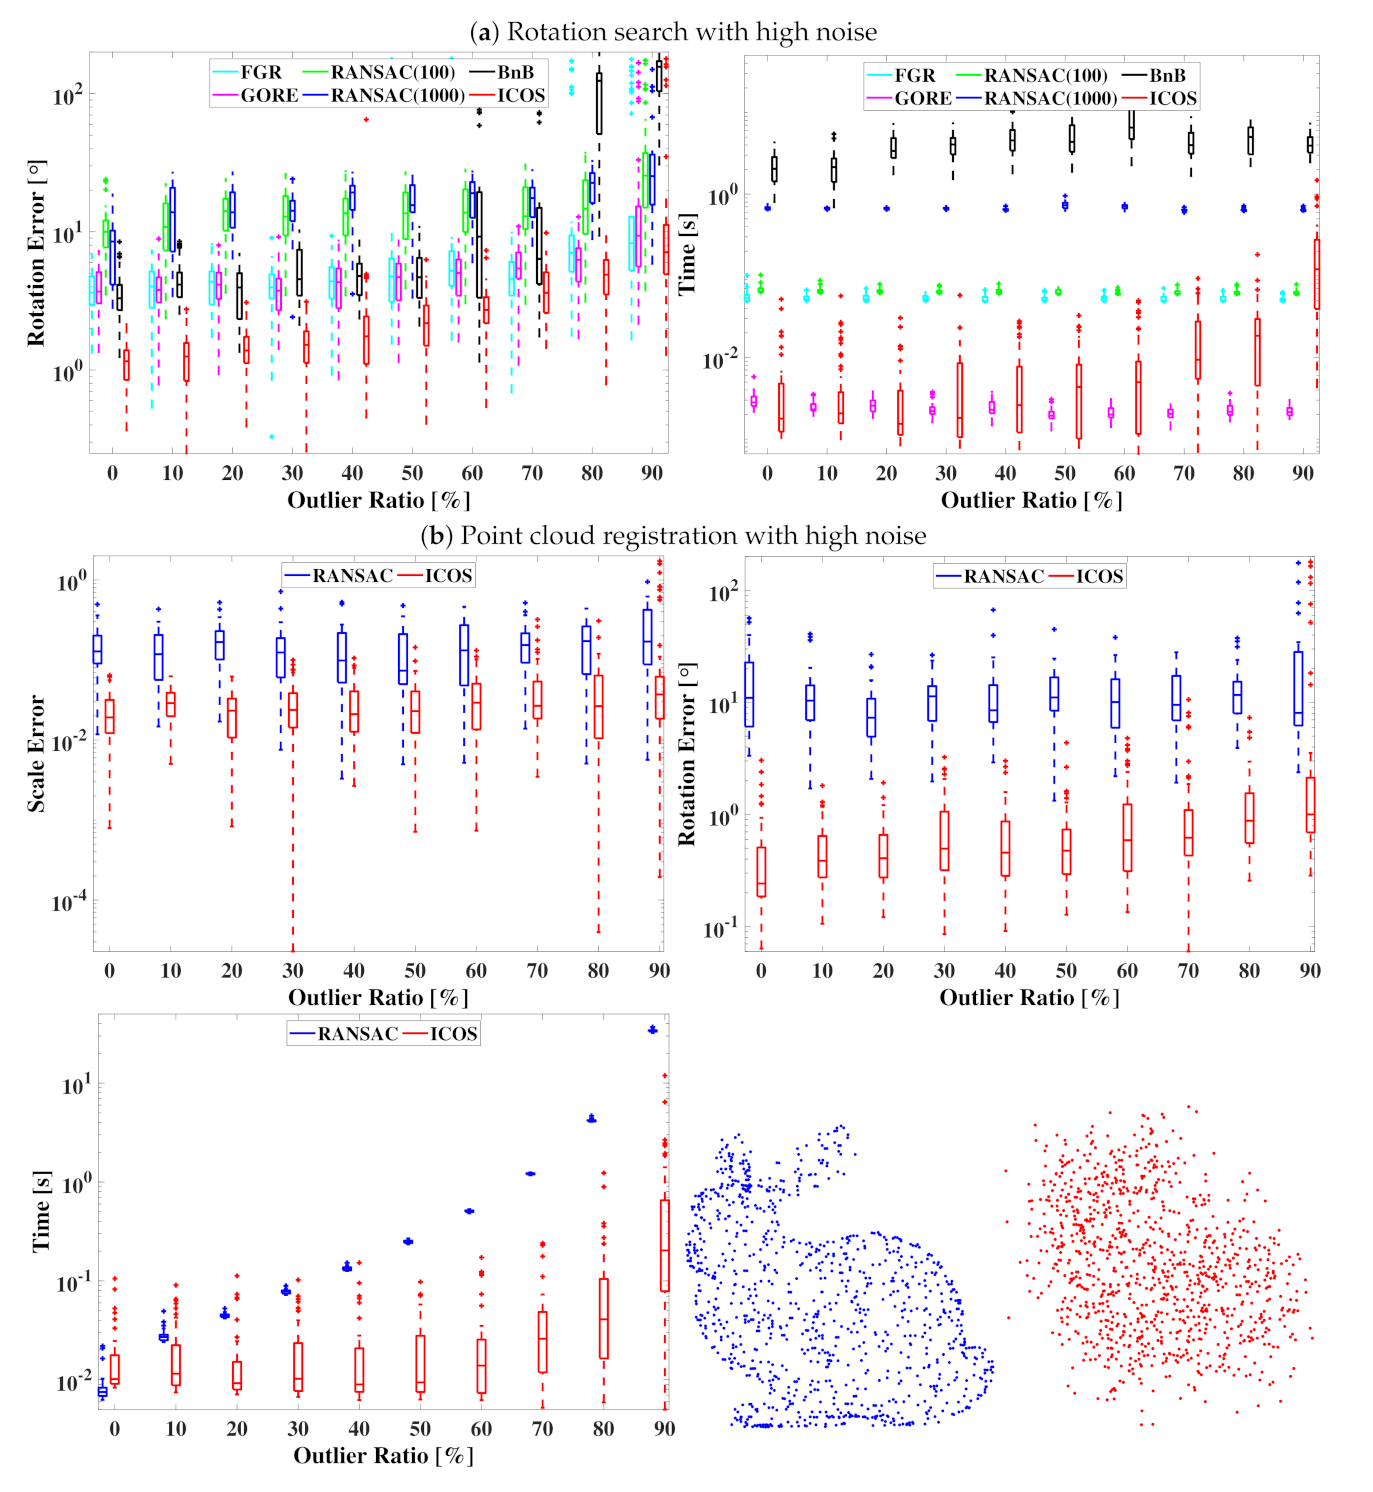
6.6. Additional Benchmarking on High Noise
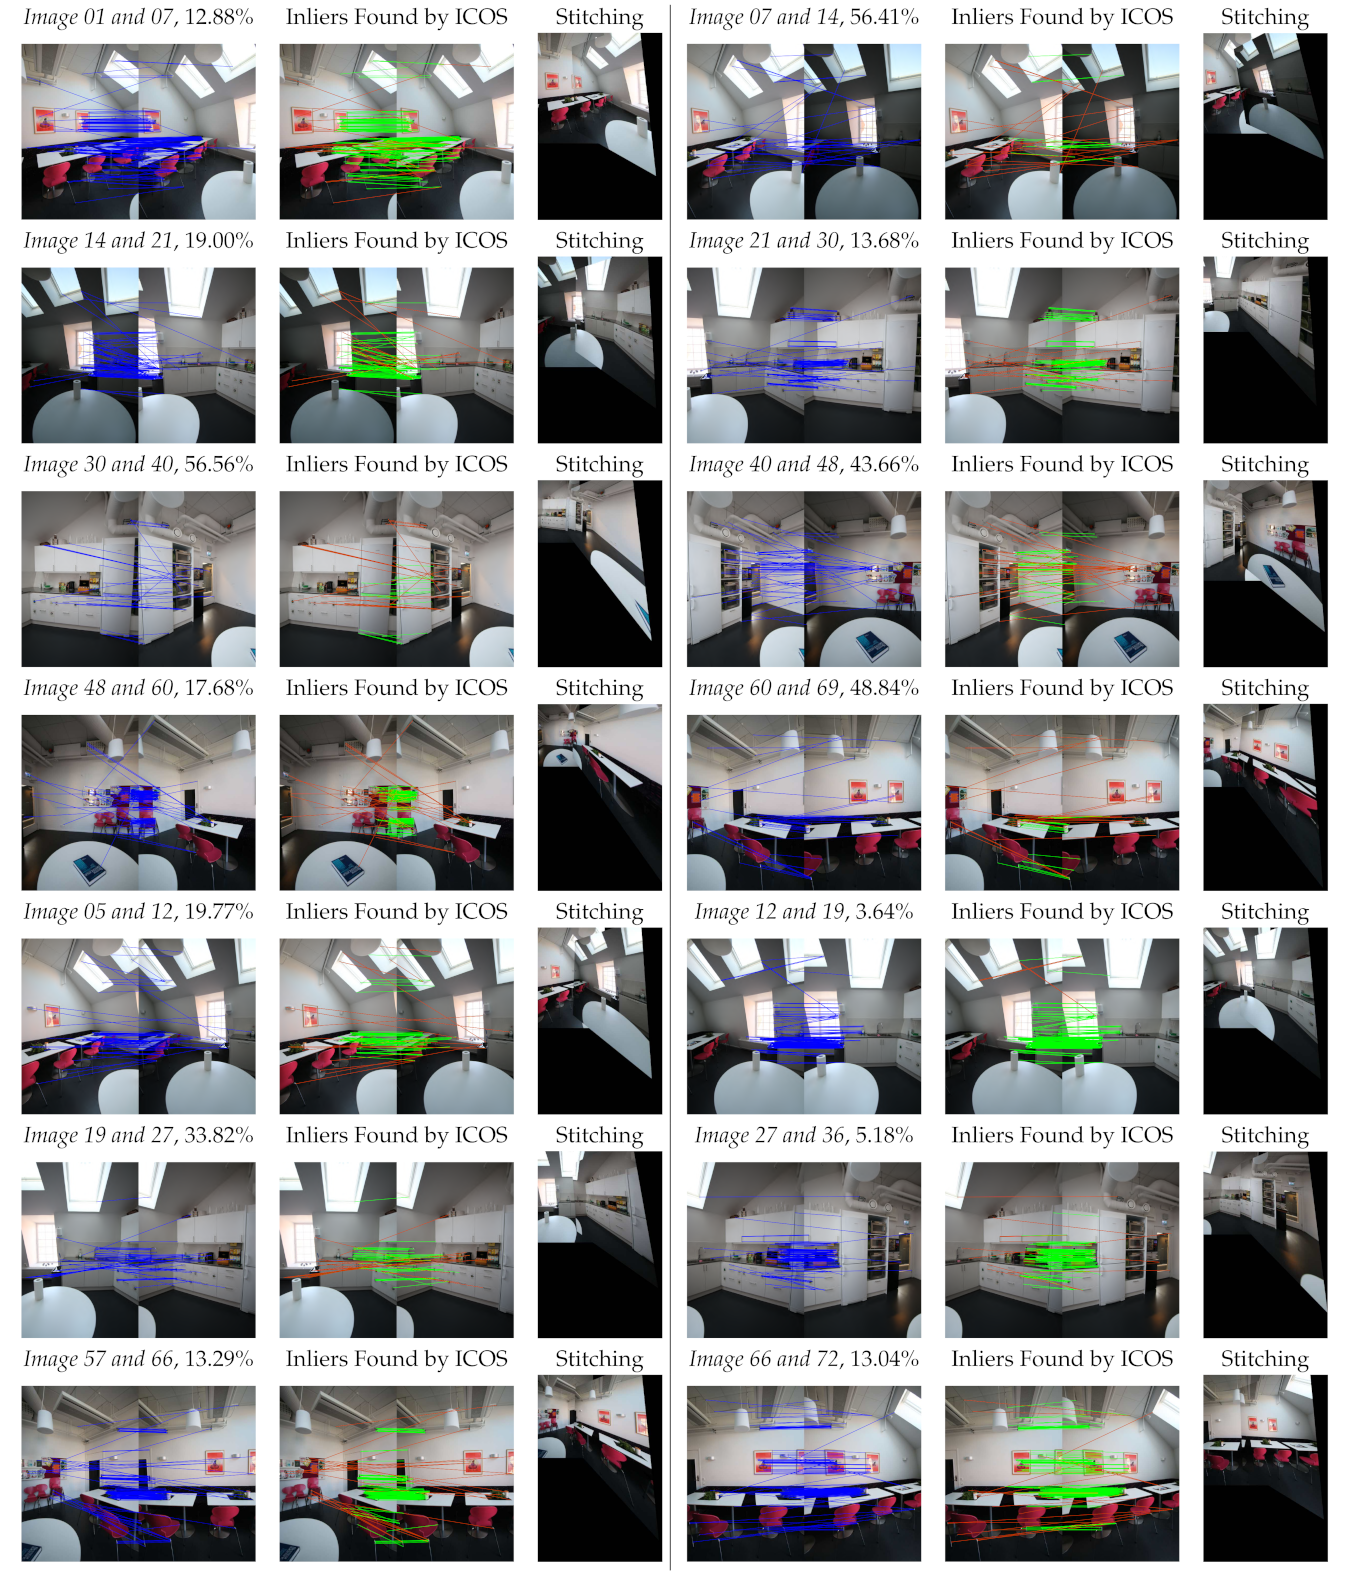
6.7. Application 1: Image Stitching
6.8. Application 2: 3D Object Localization
7. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Wahba, G. A least squares estimate of satellite attitude. SIAM Rev. 1965, 7, 409. [Google Scholar] [CrossRef] [Scilit]
- Bazin, J.C.; Seo, Y.; Hartley, R.; Pollefeys, M. Globally Optimal Inlier Set Maximization with Unknown Rotation and Focal Length; European Conference on Computer Vision; Springer: Berlin/Heidelberg, Germany, 2014; pp. 803–817. [Google Scholar]
- Heo, J.; Jeong, S.; Park, H.K.; Jung, J.; Han, S.; Hong, S.; Sohn, H.G. Productive high-complexity 3D city modeling with point clouds collected from terrestrial LiDAR. Comput. Environ. Urban Syst. 2013, 41, 26–38. [Google Scholar] [CrossRef] [Scilit]
- Blais, G.; Levine, M.D. Registering multiview range data to create 3D computer objects. IEEE Trans. Pattern Anal. Mach. Intell. 1995, 17, 820–824. [Google Scholar] [CrossRef] [Scilit]
- Henry, P.; Krainin, M.; Herbst, E.; Ren, X.; Fox, D. RGB-D mapping: Using Kinect-style depth cameras for dense 3D modeling of indoor environments. Int. J. Robot. Res. 2012, 31, 647–663. [Google Scholar] [CrossRef] [Scilit]
- Choi, S.; Zhou, Q.Y.; Koltun, V. Robust reconstruction of indoor scenes. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Santiago, Chile, 13–16 December 2015; pp. 5556–5565. [Google Scholar]
- Drost, B.; Ulrich, M.; Navab, N.; Ilic, S. Model globally, match locally: Efficient and robust 3D object recognition. In Proceedings of the 2010 IEEE Computer Society Conference on Computer Vision and Pattern Recognition, San Francisco, CA, USA, 13–18 June 2010; pp. 998–1005. [Google Scholar]
- Papazov, C.; Haddadin, S.; Parusel, S.; Krieger, K.; Burschka, D. Rigid 3D geometry matching for grasping of known objects in cluttered scenes. Int. J. Robot. Res. 2012, 31, 538–553. [Google Scholar] [CrossRef] [Scilit]
- Guo, Y.; Bennamoun, M.; Sohel, F.; Lu, M.; Wan, J. 3D object recognition in cluttered scenes with local surface features: A survey. IEEE Trans. Pattern Anal. Mach. Intell. 2014, 36, 2270–2287. [Google Scholar] [CrossRef] [Scilit]
- Audette, M.A.; Ferrie, F.P.; Peters, T.M. An algorithmic overview of surface registration techniques for medical imaging. Med. Image Anal. 2000, 4, 201–217. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Singh, S. LOAM: Lidar Odometry and Mapping in Real-Time. In Proceedings of the Robotics: Science and Systems, Berkeley, CA, USA, 12–16 July 2014; Volume 2. [Google Scholar]
- Chase, A.F.; Chase, D.Z.; Fisher, C.T.; Leisz, S.J.; Weishampel, J.F. Geospatial revolution and remote sensing LiDAR in Mesoamerican archeology. Proc. Natl. Acad. Sci. USA 2012, 109, 12916–12921. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Tron, R.; Rosen, D.M.; Carlone, L. On the inclusion of determinant constraints in lagrangian duality for 3D SLAM. In Proceedings of the Robotics: Science and Systems (RSS), Workshop the Problem of Mobile Sensors: Setting Future Goals and Indicators of Progress for SLAM, Rome, Italy, 13–17 July 2015; Volume 4. [Google Scholar]
- Briales, J.; Gonzalez-Jimenez, J. Convex global 3d registration with lagrangian duality. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Honolulu, HI, USA, 22–25 July 2017; pp. 4960–4969. [Google Scholar]
- Lowe, D.G. Object recognition from local scale-invariant features. In Proceedings of the Seventh IEEE International Conference on Computer Vision, Kerkyra, Greece, 20–27 September 1999; Volume 2, pp. 1150–1157. [Google Scholar]
- Bay, H.; Ess, A.; Tuytelaars, T.; Van Gool, L. Speeded-up robust features (SURF). Comput. Vis. Image Underst. 2008, 110, 346–359. [Google Scholar] [CrossRef] [Scilit]
- Rusu, R.B.; Blodow, N.; Marton, Z.C.; Beetz, M. Aligning point cloud views using persistent feature histograms. In Proceedings of the 2008 IEEE/RSJ International Conference on Intelligent Robots and Systems, Nice, France, 22–26 September 2008; pp. 3384–3391. [Google Scholar]
- Fischler, M.A.; Bolles, R.C. Random sample consensus: A paradigm for model fitting with applications to image analysis and automated cartography. Commun. ACM 1981, 24, 381–395. [Google Scholar] [CrossRef] [Scilit]
- Hartley, R.; Zisserman, A. Multiple View Geometry in Computer Vision; Cambridge University Press: Cambridge, UK, 2004. [Google Scholar]
- Bustos, A.P.; Chin, T.J. Guaranteed outlier removal for point cloud registration with correspondences. IEEE Trans. Pattern Anal. Mach. Intell. 2017, 40, 2868–2882. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Parra Bustos, A.; Chin, T.J. Guaranteed outlier removal for rotation search. In Proceedings of the IEEE International Conference on Computer Vision, Santiago, Chile, 7–13 December 2015; pp. 2165–2173. [Google Scholar]
- Zhou, Q.Y.; Park, J.; Koltun, V. Fast Global Registration; European Conference on Computer Vision; Springer: Berlin/Heidelberg, Germany, 2016; pp. 766–782. [Google Scholar]
- Yang, H.; Carlone, L. A quaternion-based certifiably optimal solution to the Wahba problem with outliers. In Proceedings of the IEEE/CVF International Conference on Computer Vision, Seoul, Korea, 27 October–2 November 2019; pp. 1665–1674. [Google Scholar]
- Yang, H.; Carlone, L. A Polynomial-time Solution for Robust Registration with Extreme Outlier Rates. In Proceedings of the Robotics: Science and Systems, Freiburg im Breisgau, Germany, 22–26 June 2019. [Google Scholar]
- Yang, H.; Shi, J.; Carlone, L. Teaser: Fast and certifiable point cloud registration. IEEE Trans. Robot. 2020, 37, 1665–1674. [Google Scholar]
- Zeisl, B.; Koser, K.; Pollefeys, M. Automatic registration of RGB-D scans via salient directions. In Proceedings of the IEEE International Conference on Computer Vision, Sydney, Australia, 3–6 December 2013; pp. 2808–2815. [Google Scholar]
- Shi, J.; Yang, H.; Carlone, L. ROBIN: A Graph-Theoretic Approach to Reject Outliers in Robust Estimation using Invariants. arXiv 2020, arXiv:2011.03659. [Google Scholar]
- Chum, O.; Matas, J.; Kittler, J. Locally optimized RANSAC. In Joint Pattern Recognition Symposium; Springer: Berlin/Heidelberg, Germany, 2003; pp. 236–243. [Google Scholar]
- Lebeda, K.; Matas, J.; Chum, O. Fixing the Locally Optimized Ransac–Full Experimental Evaluation. In Proceedings of the British Machine Vision Conference, Surrey, UK, 3–7 September 2012; Volume 2. [Google Scholar]
- Horn, B.K.; Hilden, H.M.; Negahdaripour, S. Closed-form solution of absolute orientation using orthonormal matrices. JOSA A 1988, 5, 1127–1135. [Google Scholar] [CrossRef] [Scilit]
- Markley, F.L. Attitude determination using vector observations and the singular value decomposition. J. Astronaut. Sci. 1988, 36, 245–258. [Google Scholar]
- Arun, K.S.; Huang, T.S.; Blostein, S.D. Least-squares fitting of two 3-D point sets. IEEE Trans. Pattern Anal. Mach. Intell. 1987, 698–700. [Google Scholar] [CrossRef] [Scilit]
- Forbes, J.R.; de Ruiter, A.H. Linear-matrix-inequality-based solution to wahbas problem. J. Guid. Control. Dyn. 2015, 38, 147–151. [Google Scholar] [CrossRef] [Scilit]
- Horn, B.K. Closed-form solution of absolute orientation using unit quaternions. JOSA A 1987, 4, 629–642. [Google Scholar] [CrossRef] [Scilit]
- Markley, F.L.; Crassidis, J.L. Fundamentals of Spacecraft Attitude Determination and Control; Springer: Berlin/Heidelberg, Germany, 2014. [Google Scholar]
- Hartley, R.I.; Kahl, F. Global optimization through rotation space search. Int. J. Comput. Vis. 2009, 82, 64–79. [Google Scholar] [CrossRef] [Scilit]
- Bazin, J.C.; Seo, Y.; Pollefeys, M. Globally optimal consensus set maximization through rotation search. In Proceedings of the Asian Conference on Computer Vision, Daejeon, Korea, 5–9 November 2012; pp. 539–551. [Google Scholar]
- Parra Bustos, A.; Chin, T.J.; Suter, D. Fast rotation search with stereographic projections for 3d registration. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, Columbus, OH, USA, 23–28 June 2014; pp. 3930–3937. [Google Scholar]
- Besl, P.; McKay, N.D. A method for registration of 3-D shapes. IEEE Trans. Pattern Anal. Mach. Intell. 1992, 14, 239–256. [Google Scholar] [CrossRef] [Scilit]
- Tam, G.K.; Cheng, Z.Q.; Lai, Y.K.; Langbein, F.C.; Liu, Y.; Marshall, D.; Martin, R.R.; Sun, X.F.; Rosin, P.L. Registration of 3D point clouds and meshes: A survey from rigid to nonrigid. IEEE Trans. Vis. Comput. Graph. 2012, 19, 1199–1217. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhong, Y. Intrinsic shape signatures: A shape descriptor for 3d object recognition. In Proceedings of the 2009 IEEE 12th International Conference on Computer Vision Workshops, ICCV Workshops, Kyoto, Japan, 29 September–2 October 2009; pp. 689–696. [Google Scholar]
- Choy, C.; Park, J.; Koltun, V. Fully convolutional geometric features. In Proceedings of the IEEE/CVF International Conference on Computer Vision, Seoul, Korea, 27 October–2 November 2019; pp. 8958–8966. [Google Scholar]
- Olsson, C.; Kahl, F.; Oskarsson, M. Branch-and-bound methods for euclidean registration problems. IEEE Trans. Pattern Anal. Mach. Intell. 2008, 31, 783–794. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, J.; Hu, Q.; Ai, M. Point Cloud Registration Based on One-Point RANSAC and Scale-Annealing Biweight Estimation. IEEE Trans. Geosci. Remote. Sens. 2021. [Google Scholar] [CrossRef] [Scilit]
- Huber, P.J. Robust Statistics; John Wiley & Sons: Hoboken, NJ, USA, 2004; Volume 523. [Google Scholar]
- Meer, P. Robust techniques for computer vision. Emerg. Top. Comput. Vis. 2004, 107–190. [Google Scholar]
- Mittal, S.; Anand, S.; Meer, P. Generalized projection-based M-estimator. IEEE Trans. Pattern Anal. Mach. Intell. 2012, 34, 2351–2364. [Google Scholar] [CrossRef] [Scilit]
- Yang, H.; Antonante, P.; Tzoumas, V.; Carlone, L. Graduated non-convexity for robust spatial perception: From nonminimal solvers to global outlier rejection. IEEE Robot. Autom. Lett. 2020, 5, 1127–1134. [Google Scholar] [CrossRef] [Scilit]
- Sun, L. RANSIC: Fast and Highly Robust Estimation for Rotation Search and Point Cloud Registration using Invariant Compatibility. arXiv 2021, arXiv:2104.09133. [Google Scholar]
- Barfoot, T.D. State Estimation for Robotics; Cambridge University Press: Cambridge, UK, 2017. [Google Scholar]
- Hartley, R.; Trumpf, J.; Dai, Y.; Li, H. Rotation averaging. Int. J. Comput. Vis. 2013, 103, 267–305. [Google Scholar] [CrossRef] [Scilit]
- Curless, B.; Levoy, M. A volumetric method for building complex models from range images. In Proceedings of the 23rd Annual Conference on Computer Graphics and Interactive Techniques, New York, NY, USA, 4–9 August 1996; pp. 303–312. [Google Scholar]
- Eppstein, D.; Löffler, M.; Strash, D. Listing all maximal cliques in sparse graphs in near-optimal time. In International Symposium on Algorithms and Computation; Springer: Berlin/Heidelberg, Germany, 2010; pp. 403–414. [Google Scholar]
- Rusu, R.B.; Blodow, N.; Beetz, M. Fast point feature histograms (FPFH) for 3D registration. In Proceedings of the 2009 IEEE International Conference on Robotics and Automation, Kobe, Japan, 12–19 May 2009; pp. 3212–3217. [Google Scholar]
- Meneghetti, G.; Danelljan, M.; Felsberg, M.; Nordberg, K. Image alignment for panorama stitching in sparsely structured environments. In Proceedings of the Scandinavian Conference on Image Analysis, Copenhagen, Denmark, 15–17 June 2015; pp. 428–439. [Google Scholar]
- Lai, K.; Bo, L.; Ren, X.; Fox, D. A large-scale hierarchical multi-view rgb-d object dataset. In Proceedings of the 2011 IEEE International Conference on Robotics and Automation, Shanghai, China, 9–13 May 2011; pp. 1817–1824. [Google Scholar]




| Algorithm 1 | Algorithm 3 | Algorithm 4 |
|---|---|---|
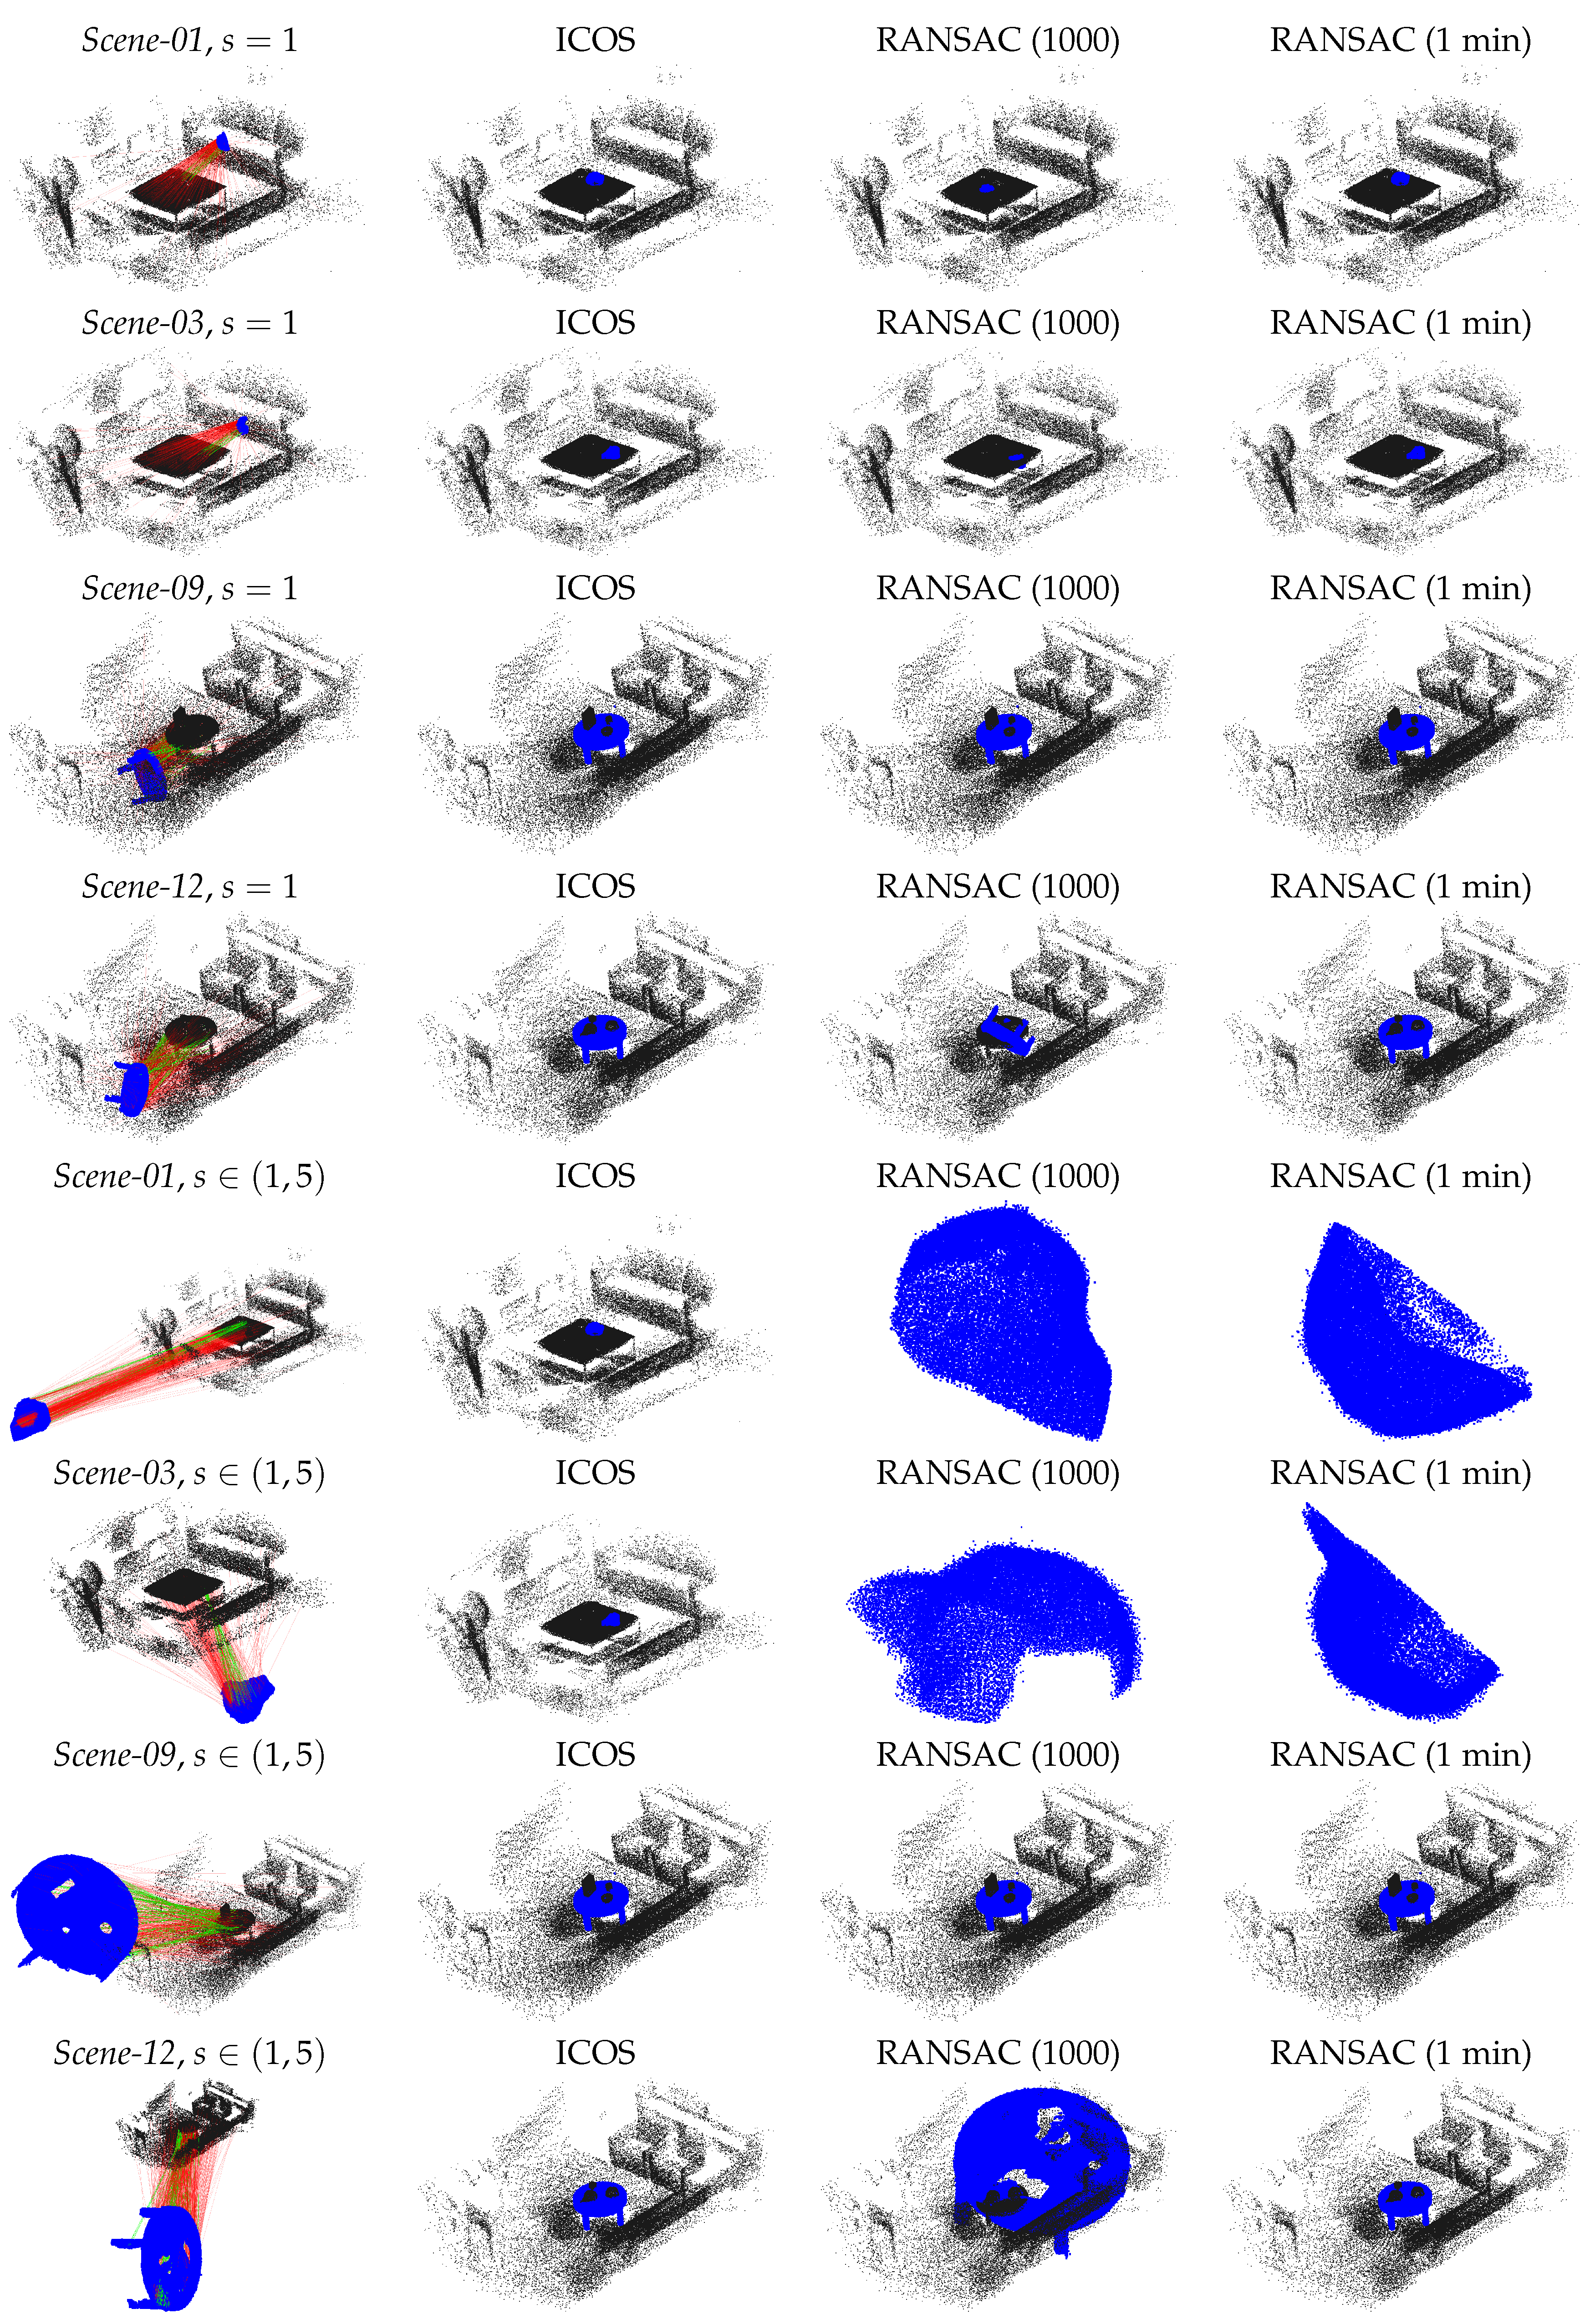
| Scene No. | ICOS | RANSAC (1000) | RANSAC (1 min) |
|---|---|---|---|
| Scene-02, | 0.196 | ||
| , 93.80% | |||
| Scene-05, | |||
| , 90.92% | |||
| Scene-07, | |||
| , 81.53% | |||
| Scene-09, | |||
| , 90.16% | |||
| Scene-02, | |||
| , 94.82% | |||
| Scene-05, | |||
| , 95.14% | |||
| Scene-07, | |||
| , 92.43% | |||
| Scene-09, | |||
| , 95.26% | |||
| Scene No. | ICOS | RANSAC (1000) | RANSAC (1 min) |
|---|---|---|---|
| Scene-01, | 0.151 | ||
| , 90.91% | |||
| Scene-03, | |||
| , 94.62% | |||
| Scene-09, | |||
| , 86.18% | |||
| Scene-12, | |||
| , 89.98% | |||
| Scene-01, | |||
| , 94.99% | |||
| Scene-03, | |||
| , 91.88% | |||
| Scene-09, | |||
| , 80.94% | |||
| Scene-12, | |||
| , 89.54% | |||
Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2021 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).
Share and Cite
Sun, L.; Deng, Z. A Fast and Robust Rotation Search and Point Cloud Registration Method for 2D Stitching and 3D Object Localization. Appl. Sci. 2021, 11, 9775. https://doi.org/10.3390/app11209775
Sun L, Deng Z. A Fast and Robust Rotation Search and Point Cloud Registration Method for 2D Stitching and 3D Object Localization. Applied Sciences. 2021; 11(20):9775. https://doi.org/10.3390/app11209775
Chicago/Turabian StyleSun, Lei, and Zhongliang Deng. 2021. "A Fast and Robust Rotation Search and Point Cloud Registration Method for 2D Stitching and 3D Object Localization" Applied Sciences 11, no. 20: 9775. https://doi.org/10.3390/app11209775
APA StyleSun, L., & Deng, Z. (2021). A Fast and Robust Rotation Search and Point Cloud Registration Method for 2D Stitching and 3D Object Localization. Applied Sciences, 11(20), 9775. https://doi.org/10.3390/app11209775