


Abstract
Eigenvector sensitivities are often used in many engineering problems such as structural vibration control, optimization design, model updating and damage identification. So far, modal superposition method and Nelson’s method are the two main methods for exactly calculating eigenvector sensitivities. However, modal superposition method has a great limitation in applications because it needs all the eigenvectors in its calculation. Although Nelson’s method does not need to use all the eigenvectors, there is no unified sensitivity calculation formula for each eigenvector. In this paper, a new exact method for calculating the eigenvector sensitivity is proposed. The explicit expressions for the first-order and second-order sensitivities of eigenvectors are derived, and strict proof is given. The developed eigenvector sensitivity formulas are simple and convenient in programming. The proposed method is as powerful as Nelson’s method, but much more easy to use. Two numerical examples are used to demonstrate the proposed method and the results show that the developed eigenvector sensitivity formulas are exact and reliable.
1. Introduction
In structural vibration modal analysis, the eigenvalue (square of frequency) and eigenvector (mode shape) are the two important parameters and their sensitivities are often used in many engineering problems such as structural vibration control [1,2,3,4,5,6], optimization design [7,8,9], model updating [10,11,12,13,14] and damage identification [15,16,17]. From the current research literature, the calculation formula of eigenvalue sensitivity is simple, but the calculating formula for eigenvector sensitivity is complicated. At present, there are two kinds of methods to calculate the sensitivities of eigenvectors: exact methods and approximate methods. The classical exact methods are modal superposition method [18] and Nelson’s method [19]. The basic principle of mode superposition method is to express the eigenvector sensitivity as a linear combination of all modes. Thus modal superposition method has a great limitation in application because only partial modes are available for large-scale structures. Lim et al. [20] studied the improved modal superposition method by approximating the eigenvector derivatives using only the available lower modes. Zhang and Zerva [21,22] proposed an iterated modal superposition method to further improve numerical accuracy. Their method was only efficient for the case of limited numbers of design variables. Balmes [23] improved the computational efficiency of modal superposition method by using fixed basis model reduction technique. The modal superposition method has also been developed to treat with the damping systems [24,25], and complex-valued systems [26,27] by some researchers. In general, the calculation formulas of modal superposition method and its improved methods are complicated, especially for the higher-order sensitivity analysis. Compared with modal superposition method, Nelson’s method and its extended methods have an obvious advantage that only the eigenvector of interest is required. Lin et al. [28,29] improved the computational efficiency of Nelson’s method by using inverse iteration and model reduction techniques. Adhikari and Friswell [30] used Nelson’s method to calculate the derivatives of the eigenvalues and eigenvectors for nonviscously damped systems. Wu et al. [31] presented an improved Nelson’s Method for computing eigenvector derivatives with distinct and repeated eigenvalues. The improvement of their method is mainly to reduce the condition number of coefficient matrix. Guedria et al. [32] extended Nelson’s approach to the computation of the second-order eigenpair derivatives for symmetric and asymmetric damped systems with distinct eigenvalues. Using generalized inverse, Wang and Dai [33,34] further extended Nelson’s method to the calculation of eigensensitivities for symmetric and asymmetric damped systems with repeated eigenvalues. Ruiz et al. [35] studied the computation method of eigenvector sensitivity in structural and topology optimization problems. They proposed a general framework for computing eigenvector sensitivity whenever tracking specific mode shapes selected beforehand. Lin and Ng [36] studied the computation problem of eigenpair sensitivities for fractional vibration systems. Their work examined how eigenvalue and eigenvector derivatives of fractional systems can be derived when system matrices become functions of physical design parameters. Although Nelson’s method and the above extended methods do not need to use all eigenvectors, there is no unified sensitivity calculation formula for each eigenvector, and the operation steps are slightly cumbersome. In view of this, this work presents a new exact method for calculating the sensitivities of eigenvectors. The explicit expressions for the first-order and second-order sensitivities of eigenvectors are derived, and strict proof is given. These formulas are simple and convenient in programming. The proposed method is as powerful as Nelson’s method, but much more easy to use. Two numerical examples are used to demonstrate the proposed method and the results show that the developed eigenvector sensitivity formulas are exact and reliable.
2. The Classical Exact Methods
In this section, modal superposition method [18] and Nelson’s method [19] are briefly reviewed for calculating the eigenvector sensitivity. Assuming structural stiffness and mass matrices with degrees of freedom (DOFs) are and , the eigenvalue and eigenvector of the system can be obtained by solving the following generalized eigenvalue problem as:
where and are the th eigenvalue and eigenvector, . Apparently, ,, and are the functions of the design parameters such as elastic modulus, cross sectional area and density. By taking partial derivative of Equation (1) with respect to , one has:
where is defined as the first-order eigenvalue sensitivity and is defined as the first-order eigenvector sensitivity. By transposing Equation (1) and using the symmetry of and , one has:
Multiplying Equation (3) by and using Equations (2) and (4), one can obtain the calculation formula of the eigenvalue sensitivity as:
Apparently, Equation (5) is simple and easy to program. Next, it focuses on the calculation method of eigenvector sensitivity. As mentioned before, the calculation formula of eigenvector sensitivity is relatively complex. The modal superposition method and Nelson’s method are briefly described as follows:
2.1. Modal Superposition Method
Fox and Kapoor [18] put forward the modal superposition method for the calculation of eigenvector sensitivity. The basic idea of the method is to express the eigenvector sensitivity as the linear combination of all eigenvectors. The calculation formulas are as follows:
Obviously, all eigenvectors must be used in Equation (6). In practice, the computation of the high-order eigenvectors of the large-scale structures is time-consuming and inaccurate. Thus the modal superposition method has great limitations in application.
2.2. Nelson’s Method
Nelson’s method [19] has the great advantage that only the eigenvector of interest is required. Its basic idea is to convert the eigenvector sensitivity into the sum of the general solution and the special solution of Equation (3). Then the general solution and the special solution are solved, respectively. The specific operation steps are as follows:
Letting
Then Equation (3) simplifies to:
Since the matrix in Equation (11) is a singular matrix, it is impossible to directly calculate by using the matrix inverse technique. From Equation (11), can be expressed as the sum of the general solution and a special solution of Equation (11). According to Equation (1), the general solution (singular solution) of Equation (11) is . Assuming a special solution of Equation (11) is , one has
The next task is to solve the special solution and the coefficient . In order to find the special solution, Equation (11) can be constrained and rewritten as
where is a nonsingular matrix obtained by replacing the elements in of the row and the column with 0, and replacing the element with 1. Here the represents the row number of the largest element in . is obtained by replacing the element in the row of with 0. From Equation (13), the special solution can be obtained as
by taking partial derivative of Equation (2) with respect to , one has
substituting Equation (12) into Equation (15), the coefficient can obtained as
It can be seen from the above processes that Nelson’s method needs several operation steps. There is no unified formula for calculating the sensitivities of different eigenvectors, since the positions of the largest elements in different eigenvectors are always changing in the process of finding specific solutions.
3. The New Exact Method for Eigenvector Sensitivities
In view of the shortcomings of existing methods, the paper proposes a new exact method for calculating the eigenvector sensitivity. The main formulas are derived as follows.
Firstly, Equation (3) can be rewritten by adding a term of as
substituting Equation (6) into yields
according to the orthogonally of eigenvectors, one has
substituting Equations (2) and (19) into Equation (18), one can obtain
substituting Equation (20) into Equation (17) yields
where
If the matrix is full rank, the eigenvector sensitivity can be directly computed from Equation (21) as:
The proposition that the matrix is full rank can be proved as follows.
Proof.
To prove the above proposition, it is necessary to use for reference the related viewpoints and proof process of the Cayley–Hamilton theorem. Matrix diagonalization is one of the common techniques used in the proof of Cayley–Hamilton theorem. Therefore, in the next proof process, matrix diagonalization is also used as the main tool to simplify the matrix . Letting
It is clear that the matrix consisting of all the eigenvectors is full rank. Then the original proposition “ is full rank” can be equivalent to the new proposition “ is full rank”. Using Equations (22) and (25), can be expanded as
where
Substituting Equations (27)–(29) into Equation (26) yields
Now the proposition is full rank can be equivalent to the new proposition “the Equation only has zero solution”. Using Equation (30), can be simplified as
from the th row of Equation (31), one has
substituting Equation (32) into Equation (31), one can obtain
Equation (33) means that the equation only has zero solution. Thus the matrix is full rank. It proved that the matrix is full rank.
End (End of the proof). □
It must be pointed out that only systems with distinct eigenvalues are considered in this paper. If there exists two different eigenvectors with the same eigenvalue, the matrix presented in Equation (30) is not at full rank and therefore the above thesis will be invalid. The problem is known and presented in the published literature. The existing methods to address this problem can be found in references [23,31,33,34,35]. How to extend the proposed method to the systems with repeated eigenvalues will be further studied in the future.
Equation (24) is the proposed new formula for calculating the first-order sensitivity of the eigenvector. Obviously, this formula has the advantage of requiring only the knowledge of the eigenvector to be differentiated, and there is no need for multi-step operations like Nelson’s method. The formula is concise and can be applied to any eigenvector.
Another advantage of the proposed method is that it can be easily extended to the calculations of the second- and higher order sensitivities of eigenvectors. Without loss of generality, the calculation formulas of the second-order sensitivity are derived as follows. Differentiating Equation (3) a second time with respect to a (possibly) different parameter , one has
Multiplying Equation (34) by and using Equations (2) and (4), the second sensitivity of can be obtained as:
It is clear that Equation (35) only requires the first-order sensitivities of the eigenvalues and eigenvectors for the calculation of the second-order eigenvalue sensitivity.
The second-order sensitivity of eigenvector can be directly computed from Equation (21). Differentiating Equation (21) a second time with respect to gives
Then the second-order eigenvector sensitivity can be computed from Equation (36) as:
where
From Equation (8), in Equation (39) can be computed by
4. Numerical Examples
4.1. A Truss Structure
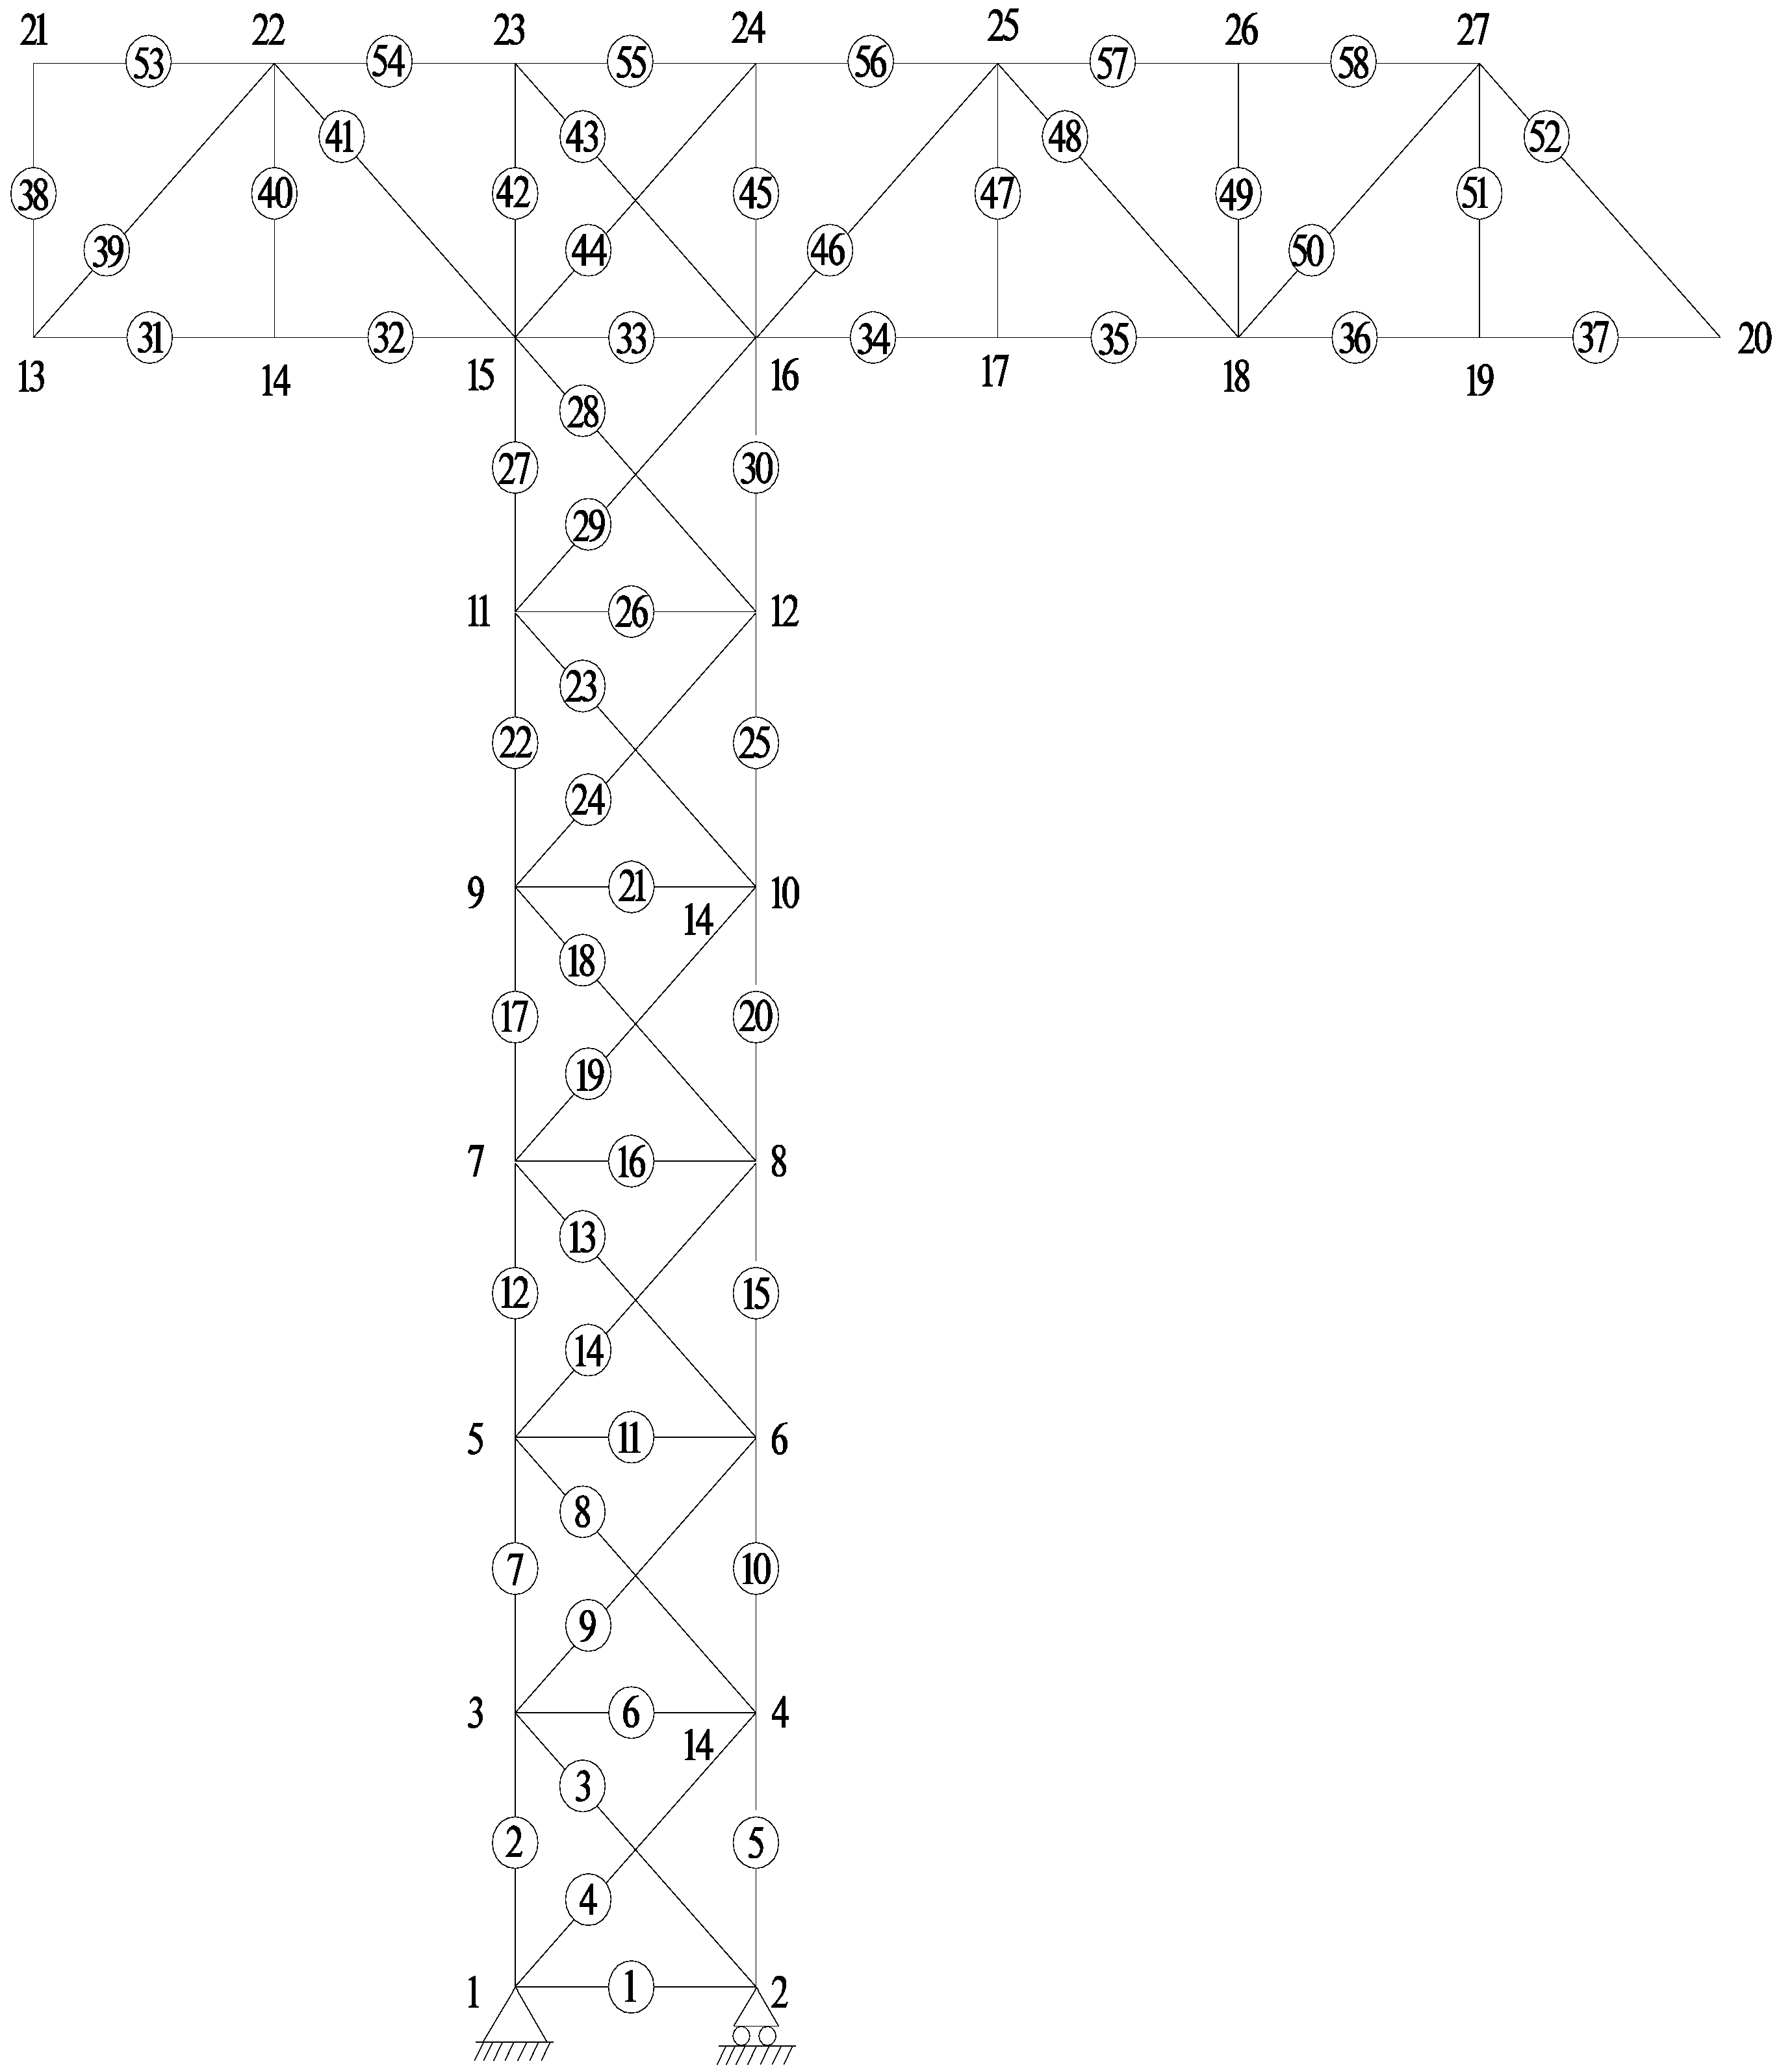
A truss structure as shown in Figure 1 is used to demonstrate the proposed method and the calculation results are compared with those obtained by the modal superposition method. The structure consists of 58 bar elements with a total of 51 DOFs. The basic physical parameters are: modulus of elasticity E = 200 GPa, density ρ = 7800 kg/m3, cross-sectional area A = 3.14 × 10⁻⁴ m2. According to the finite element model theory, structural global stiffness matrix can be expressed as the sum of all elemental stiffness matrices, that is
where and are the th elemental stiffness matrix and design parameter. Next, the proposed method (Equation (24)) is employed to calculate the eigenvector sensitivity . Without loss of generality, Table 1 and Table 2 present some results (the data corresponding to the first 20 DOFs) of , , , , , , and . For convenience of comparison, the results obtained by the modal superposition method (Equation (6)) are also given in Table 1 and Table 2. One can see from Table 1 and Table 2 that the proposed method can obtain the same calculation results as those of the modal superposition method. It has been shown that the proposed method is an exact method and easier to operate.
Figure 1.
A truss structure.
Table 1.
Comparison of the calculation results for the first eigenvector sensitivity (×10−3).
Table 2.
Comparison of the calculation results for the second eigenvector sensitivity (×10−3).
4.2. A Spring-Mass System
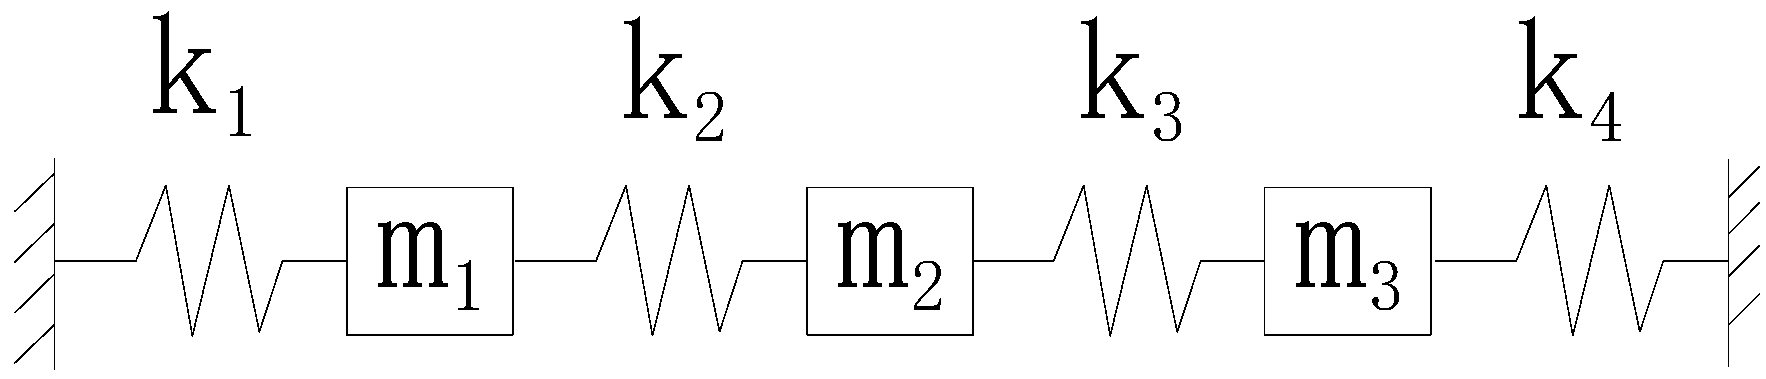
The second example is the spring-mass system (shown in Figure 2) used by Friswell [37], which is employed to further verify the proposed second-order sensitivity formula of eigenvector. The nominal model of the system has the parameters , and .
Figure 2.
Spring-mass system for example 2.
Two parameters will be allowed to vary, namely (equivalent to ) and (equivalent to ). The mass and stiffness matrices and their nonzero derivatives are
The first eigenvalue and eigenvector can be computed as
Using Equation (24), and can be calculated as
Using Equation (35), the second-order sensitivities of eigenvalue can be obtained as
Using Equation (37), the second-order sensitivities of eigenvector can be obtained as
The above results are the same as those obtained by Friswell in reference [37]. It has been shown that the proposed method is exact and reliable.
4.3. A System with Similar Eigenvalues
The third example is a simple eigenvalue problem, which is used to discuss the stability of the methodology in the case of “close modes” (with very similar eigenvalues). The mass and stiffness matrices of the system are
At , the eigenvalues of are = 0.8890, = 0.9900 and = 0.9901. It is clear that and are very close. Table 3 presents the eigenvector sensitivities computed by the proposed method and the modal superposition method. From Table 3, one can see that the proposed method can obtain the same calculation results as those of the modal superposition method. To a certain extent, these results show that the proposed method can be used to solve the eigenvalue problem with close modes.
Table 3.
Eigenvector sensitivities obtained by the proposed method and the modal superposition method.
5. Conclusions
In this paper, a new exact method for calculating the sensitivities of eigenvectors is proposed. The explicit expressions for the first-order and second-order sensitivities of eigenvectors are derived, and a strict proof is given. The method has the advantage of requiring only the knowledge of the eigenvector to be differentiated. The developed eigenvector sensitivity formulas are simple and convenient in programming. Two numerical examples are used to demonstrate the proposed method and the results show that the developed method is exact and reliable. The proposed method is as powerful as Nelson’s method, but much more easy to use. The proposed method will have a broad application prospect in engineering practice. Future research on the proposed method should be carried out to tackle the cases of repeated eigenvalues, complex modes, damped systems, fractional vibration systems and so on.
Author Contributions
Conceptualization, Q.Y. and X.P.; methodology, Q.Y.; software, X.P.; validation, Q.Y. and X.P.; data curation, X.P.; writing—original draft preparation, Q.Y.; writing—review and editing, Q.Y. All authors have read and agreed to the published version of the manuscript.
Funding
This work is supported by the major special science and technology project (2019B10076) of “Ningbo science and technology innovation 2025”, the Natural Science Foundation of Zhejiang Province (LQ20E080013), and National Natural Science Foundation of China (11202138).
Conflicts of Interest
The authors declare no conflicts of interest.
Nomenclature
| , | structural stiffness and mass matrices |
| , | the th eigenvalue and eigenvector |
| the th design parameters | |
| the number of degrees of freedom | |
| , | the first-order eigenvalue and eigenvector sensitivities |
| , | the second-order eigenvalue and eigenvector sensitivities |
References
- Soong, T.; Michalakis, C. (Eds.) Passive and Active Structural Vibration Control in Civil Engineering; Springer: Berlin/Heidelberg, Germany, 2014; Volume 345. [Google Scholar]
- El-Ganaini, W.A. Duffing Oscillator Vibration Control via Suspended Pendulum. Appl. Math. Inf. Sci. 2018, 12, 203–215. [Google Scholar] [CrossRef] [Scilit]
- Li, N.; Zheng, Z.; Tian, Y.; Sun, J.-Y.; He, X.-T.; Lu, Y. Stochastic nonlinear vibration and reliability of orthotropic membrane structure under impact load. Thin-Walled Struct. 2017, 119, 247–255. [Google Scholar] [CrossRef] [Scilit]
- Hamed, Y.S.; Alharthi, M.R.; AlKhathami, H.K. Active Vibration Control of a Dynamical System Subjected to Simultaneous Excitation Forces. Int. J. Appl. Eng. Res. 2017, 12, 434–442. [Google Scholar]
- Saidi, A.; Zizouni, K.; Kadri, B.; Fali, L.; Bousserhane, I.K. Adaptive Sliding Mode Control for Semi-Active Structural Vibration Control. Stud. Inform. Control. 2019, 28, 371–380. [Google Scholar] [CrossRef] [Scilit]
- Yong, W. Research Status and Prospect of Structural Vibration Control. Int. Core J. Eng. 2019, 5, 142–144. [Google Scholar]
- Jeong, S.; Murayama, M.; Yamamoto, K. Efficient optimization design method using kriging model. J. Aircr. 2005, 42, 413–420. [Google Scholar] [CrossRef] [Scilit]
- Lingyun, W.; Mei, Z.; Guangming, W. Truss optimization on shape and sizing with frequency constraints based on genetic algorithm. Comput. Mech. 2005, 35, 361–368. [Google Scholar] [CrossRef] [Scilit]
- Yang, Q.W. Fast and Exact Algorithm for Structural Static Reanalysis Based on Flexibility Disassembly Perturbation. AIAA J. 2019, 57, 3599–3607. [Google Scholar] [CrossRef] [Scilit]
- Bartilson, D.T.; Jang, J.; Smyth, A.W. Finite element model updating using objective-consistent sensitivity-based parameter clustering and Bayesian regularization. Mech. Syst. Signal Process. 2019, 114, 328–345. [Google Scholar] [CrossRef] [Scilit]
- Yu, K.; Liang, P.; Silva, T.; Yu, K.; Mottershead, J. Parameter selection for model updating with global sensitivity analysis. Mech. Syst. Signal Process. 2019, 115, 483–496. [Google Scholar]
- Altunişik, A.C.; Karahasan, O.Ş.; Genç, A.F.; Okur, F.Y.; Gunaydin, M.; Adanur, S. Sensitivity-Based Model Updating of Building Frames using Modal Test Data. KSCE J. Civ. Eng. 2018, 22, 4038–4046. [Google Scholar]
- Deng, Z.; Guo, Z. Interval identification of structural parameters using interval overlap ratio and Monte Carlo simulation. Adv. Eng. Softw. 2018, 121, 120–130. [Google Scholar] [CrossRef] [Scilit]
- Rubio, P.-B.; Louf, F.; Chamoin, L. Fast model updating coupling Bayesian inference and PGD model reduction. Comput. Mech. 2018, 62, 1485–1509. [Google Scholar] [CrossRef] [Scilit]
- Yang, Q.; Wang, C.; Li, N.; Wang, W.; Liu, Y. Enhanced Singular Value Truncation Method for Non-Destructive Evaluation of Structural Damage Using Natural Frequencies. Materials 2019, 12, 1021. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yang, Q.W. A mixed sensitivity method for structural damage detection. Commun. Numer. Methods Eng. 2009, 25, 381–389. [Google Scholar] [CrossRef] [Scilit]
- Yang, Q.; Liu, J. A coupled method for structural damage identification. J. Sound Vib. 2006, 296, 401–405. [Google Scholar] [CrossRef] [Scilit]
- Fox, R.L.; Kapoor, M.P. Rates of change of eigenvalues and eigenvectors. AIAA J. 1968, 6, 2426–2429. [Google Scholar] [CrossRef] [Scilit]
- Nelson, R.B. Simplified calculation of eigenvector derivatives. AIAA J. 1976, 14, 1201–1205. [Google Scholar] [CrossRef] [Scilit]
- Lim, K.B.; Junkins, J.L.; Wang, B.P. Re-examination of eigenvector derivatives. J. Guid. Control. Dyn. 1987, 10, 581–587. [Google Scholar] [CrossRef] [Scilit]
- Zhang, O.; Zerva, A. Iterative method for calculating derivatives of eigenvectors. AIAA J. 1996, 34, 1088–1090. [Google Scholar] [CrossRef] [Scilit]
- Zhang, O.; Zerva, A. Accelerated iterative procedure for calculating eigenvector derivatives. AIAA J. 1997, 35, 340–348. [Google Scholar] [CrossRef] [Scilit]
- Balmes, E. Efficient sensitivity analysis based on finite element model reduction. In Proceedings of the 16th International Modal Analysis Conference, Santa Barbara, CA, USA, 8 February 1998. [Google Scholar]
- Zeng, Q.-H. Highly accurate modal method for calculating eigenvector derivatives in viscous damping systems. AIAA J. 1995, 33, 746–751. [Google Scholar] [CrossRef] [Scilit]
- Sondipon, A. Derivative of eigensolutions of nonviscously damped linear systems. AIAA J. 2002, 40, 2061–2069. [Google Scholar]
- Adhikari, S. Calculation of derivative of complex modes using classical normal modes. Comput. Struct. 2000, 77, 625–633. [Google Scholar] [CrossRef] [Scilit]
- Van Der Aa, N.P.; Ter Morsche, H.G.; Mattheij, R.R. Computation of eigenvalue and eigenvector derivatives for a general complex-valued eigensystem. Electron. J. Linear Algebra 2007, 16, 1. [Google Scholar] [CrossRef] [Scilit]
- Lin, R.M.; Lim, M.K. Structural sensitivity analysis via reduced-order analytical model. Comput. Methods Appl. Mech. Eng. 1995, 121, 345–359. [Google Scholar] [CrossRef] [Scilit]
- Lin, R.M.; Wang, Z.; Lim, M.K. A practical algorithm for the efficient computation of eigenvector sensitivities. Comput. Methods Appl. Mech. Eng. 1996, 130, 355–367. [Google Scholar] [CrossRef] [Scilit]
- Adhikari, S.; Friswell, M.I. Calculation of eigensolution derivatives for nonviscously damped systems. AIAA J. 2006, 44, 1799–1806. [Google Scholar] [CrossRef] [Scilit]
- Wu, B.; Xu, Z.; Li, Z. Improved Nelson’s Method for computing eigenvector derivatives with distinct and repeated eigenvalues. AIAA J. 2007, 45, 950–952. [Google Scholar] [CrossRef] [Scilit]
- Guedria, N.; Chouchane, M.; Smaoui, H. Second-order eigensensitivity analysis of asymmetric damped systems using Nelson’s method. J. Sound Vib. 2007, 300, 974–992. [Google Scholar] [CrossRef] [Scilit]
- Wang, P.; Dai, H. Calculation of eigenpair derivatives for asymmetric damped systems with distinct and repeated eigenvalues. Int. J. Numer. Methods Eng. 2015, 103, 501–515. [Google Scholar] [CrossRef] [Scilit]
- Wang, P.; Dai, H. Eigensensitivity of symmetric damped systems with repeated eigenvalues by generalized inverse. J. Eng. Math. 2016, 96, 201–210. [Google Scholar] [CrossRef] [Scilit]
- Ruiz, D.; Bellido, J.; Donoso, A. Eigenvector sensitivity when tracking modes with repeated eigenvalues. Comput. Methods Appl. Mech. Eng. 2017, 326, 338–357. [Google Scholar] [CrossRef] [Scilit]
- Lin, R.; Ng, T. Eigenvalue and eigenvector derivatives of fractional vibration systems. Mech. Syst. Signal Process. 2019, 127, 423–440. [Google Scholar] [CrossRef] [Scilit]
- Friswell, M.I. Calculation of second and higher order eigenvector derivatives. J. Guid. Control. Dyn. 1995, 18, 919–921. [Google Scholar] [CrossRef] [Scilit]

© 2020 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).