


Abstract
In this study, the concepts of -Caristi maps and generalized -contraction maps are introduced, and fixed-point theorems for such maps are established. A generalization of Caristi’s fixed-point theorem and Banach’s contraction principle is proved. The relationships among the various contraction conditions introduced in this paper are examined. Examples are provided to elucidate the main theorem, and applications to integral and differential equations are also discussed.
Keywords:
fixed point; contraction; generalized contraction; Caristi map; metric space; generalized metric space MSC:
47H10; 54H25
1. Introduction
In 1922, Banach [1] proved a famous fixed-point theorem, which is called the Banach contraction principle. Since then, this contraction principle has played an important role in mathematical analysis and applied mathematical analysis, and many authors have proposed generalizations and extensions of the Banach contraction principle. Many authors, such as [2,3,4,5,6] and those that are referenced in their studies, investigated various forms of contractive conditions and proved related fixed-point results.
On the one hand, many authors studied fixed-point theory in various spaces. Several authors generalized metric spaces and extended Banach’s contraction principle. For example, Huang and Zhang [7], Matthews [8], Amini-Harandi [9], and Branciari [10] introduced the concepts of cone metric spaces, partial distance spaces, metric-like spaces, and Branciari distance spaces, respectively.
Guo and Lakshmikantham [11] investigated some coupled fixed-point results by introducing the concept of coupled fixed points, and an application to coupled quasisolutions of the initial value problems for ordinary differential equations. Samet and Vetro [12] introduced the notion of n-tuple fixed points as a generalization of coupled fixed points and established related fixed-point results. Rad, Shukla, and Rahimi [13] proved that the results of n-tuple fixed points in cone metric spaces and metric-like spaces can be obtained from fixed-point theorems; the converse is also true.
Antón-Sancho [14] also studied fixed-point theory in the field of Higgs bundles, pursuing another direction of research. He proved the existence of fixed points for automorphisms of the moduli spaces of principal bundles over a compact algebraic curve, and he [15,16] obtained fixed-point results for automorphisms of the vector bundle moduli spaces and involutions of G-Higgs bundle moduli spaces.
Caristi [17] proved the fixed-point theorem in the so-called Caristi fixed-point theorem, which states that a map , where is a complete metric space, has a fixed point provided that it satisfies the following condition:
where is a lower-semicontinuous function.
After that, it was shown that this theorem is equivalent to Ekeland’s variational principle and the Bishop–Phelps theorem, which have a great number of applications in many branches of mathematics and applied mathematics and are crucial tools in many fields, including nonlinear analysis, dynamic systems, optimization theory, game theory, economics modeling, equilibrium theory, optimization problems, computational methods, variational inequalities, differential equations, integral equations and control theory, population dynamics, and epidemiological methods. It is also known as the most beautiful and useful extension of Banach’s contraction principle, and due to its importance, many authors, such as [18,19,20,21] and those that they reference in their studies, obtained generalizations and extensions of Caristi’s theorem; in addition, some authors [22,23,24,25,26] presented new proofs of Caristi’s theorem.
Very recently, Isik et al. [27] presented a generalization of Caristi’s fixed-point theorem in complete metric spaces by using the concept of the control function.
In this study, we give the concept of -Caristi maps and prove the existence of fixed points for such -Caristi maps in Branciari distance spaces. We generalize the notion of -contractions and obtain related fixed-point results in Branciari distance spaces. We examined the interrelations among the various contraction conditions presented in this paper. In addition, we present examples to analyze the main theorems, and we give applications to integral equations and differential equations.
2. Preliminaries
Jleli and Samet [28] gave the concept of -contractions and used this notion to generalize Banach’s contraction principle. Whenever is non-decreasing and satisfies () and (),
- ()
- For any sequence ,
- ()
- There are and :
Ahmad et al. [29] obtained an extension of the result of [28] to metric spaces by replacing () with the condition that
- ()
- is continuous on
Very recently, Işik et al. [27] generalized Caristi’s result in metric spaces with (), (), () and (), where
- ()
- For any ,
- ()’
- For any ,
- ()
- is strictly increasing;
- ()
- For any ,
- ()
- For any and ,
In 2000, Branciari [10] introduced the notion of Branciari distance spaces and extended the Banach contraction principle to Branciari distance spaces with two conditions:
- ()
- The topology generated by the Branciari distance is a Hausdorff space;
- ()
- Any Branciari distance is continuous in each coordinate.
Since then, the authors of [30,31] investigated the characteristics of Branciari distance spaces. They obtained the following characteristics.
- A Branciari distance does not have to be continuous at each coordinate;
- A convergent sequence does not have to be a Cauchy sequence;
- The limit of a convergent sequence is not guaranteed to be unique;
- An open ball does not necessarily need to be an open set. Hence, the existence of a topology compatible with the Branchiari distance is not guaranteed.
However, many researchers have realized that, despite the aforementioned topological disadvantages, Brancian distance spaces are attractive spaces for studying and developing fixed-point theory without additional conditions. It is for this reason that a considerable number of researchers ([30,31,32,33,34,35,36,37,38,39] and the references therein) have expressed interest in the Branciari distance spaces; consequently, they have undertaken studies of fixed-point theory in these spaces.
Recall the definition of Branciari distance spaces in [10].
Let be a given set. A map is called a Branciari distance, provided that for all and for all with ,
- (1)
- ;
- (2)
- ;
- (3)
- (trapezoidal inequality).
Here, is called a Branciari distance space.
Remark 1
([40]). For a Branciari distance space , the following holds:
- (i)
- is not reducible to a metric space;
- (ii)
- In general, the topology on B generated by ρ does not exist.
Remark 2.
A trapezoidal inequality holds whenever a triangular inequality is satisfied. However, the converse is not true. Metric spaces are included in the family of Branciari distance spaces.
The concept of convergence in Branciari distance spaces is defined similarly to that of metric spaces.
Let be a Branciari distance space and let be a sequence. Then, we say that
- (i)
- converges to if it satisfies
- (ii)
- is Cauchy whenever the condition
- (iii)
- is complete when every Cauchy sequence in B converges to a point in B.
Let be a Branciari distance space, and let be a topology on B such that, for any and any sequence
Here, is called a sequential topological space (see [34]).
A map is continuous [34] whenever the following condition holds.
For any sequence ,
In Example 1.1 ([31]) and Example 3 ([34]), we can see the properties of Branciari distance spaces.
In the following example, we can see some characteristics of sequential topology on Branciari distance spaces.
Example 1.
Let . Suppose that is a map defined by
Then, is a complete Branciari distance space.
It follows from (1) that the sequential topology on B generated by the Branciari distance space given in Example 1 is
Remark 3.
We have some properties of sequential topology and sequential continuity on Branciari distance spaces.
- (i)
- From (2), we have that the sequential topological space generated by the Branciari distance space given in Example 1 is not a Hausdorff space.
- (ii)
- ρ is not continuous with respect to because
Throughout this paper, unless otherwise stated, we let B denote a Branciari distance space with Branciari distance . In addition, we represent by the class of all self maps defined on a complete Branciari distance space B.
Lemma 1
([41]). Let be a complete Branciari distance space. Assume that is a Cauchy sequence and . If there exists such that
- (i)
- ;
- (ii)
- ;
- (iii)
- ;
- (iv)
- ,
then .
Lemma 2
([37]). Let be a Cauchy sequence such that
Then,
3. Fixed Points
We introduce the notion of the -Caristi map on Branciari distance space; it is the motivation from the paper by Isik et al.
Let be a function.
Then, we say that is a -Caristi map if there exists an lsc function , where , such that
Proposition 1.
Let be a σ-Caristi map with an lsc function , where .
For each , let
If σ is non-decreasing and satisfies the condition (), then the following hold:
- (i)
- ;
- (ii)
- ;
- (iii)
- .
Proof.
Since C is a -Caristi map, it satisfies that for all with ,
Hence, , and so . Thus, (i) is proved.
Let . Then, we have
which implies
and so
Hence, (ii) is satisfied.
Let , and let .
Then, we have that
Assume that .
Then, we obtain that
Hence,
If , then from (5), we have
which is a contradiction. Thus,
Applying () and (), we infer that
It follows from (6) and (7) that
Thus, (iii) is proved. □
Remark 4.
Proposition 1 holds whenever () and () are satisfied.
Theorem 1.
Let be a σ-Caristi map with an lsc function , where . If σ satisfies (), (), () and (), then C possesses a fixed point.
Proof.
Assume that
Let be given.
Since , we can choose a point such that
Inductively, we can construct a sequence such that
Since ,
which implies
Thus, the sequence is decreasing.
We now show that is Cauchy.
Using (9) and (), we find that
which implies
Hence,
Let be given.
From (10), there exists a positive integer N such that
Thus, we have that for all ,
Hence, is a Cauchy sequence.
By the completeness of B, there is with
Since is an lsc function and is a decreasing sequence,
We show that
If for some , then it follows from (9) and (12) that
which is a contradiction.
Thus, (13) holds.
Next, we assert that
By () and (9), we find that
Thus, from (12), we infer that
Since () is satisfied, (14) yields the following inequality:
By applying Lemma 2 to (11) to (15), we find that
which yields
Hence,
and thus,
Applying Proposition 1(iii) to , we find that
which implies that
Let
Then, we infer that
By applying Proposition 1(iii),
From (8), we infer that ,
Since is decreasing and is bounded below by a, there exists such that
By letting in Equation (17) and using (),
It follows from () that
Applying Lemma 1,
and hence,
From (16), we find that
Because , it follows from (4) that
and so
which leads to a contradiction.
Hence, C possesses a fixed point. □
Remark 5. (i) If σ is a non-decreasing function in Theorem 1, then C possesses a fixed point.
- (ii)
- Theorem 1 extends Theorem 2 of [27] to Branciari distance spaces.
We now present an example to analyze Theorem 1.
Example 2.
Let , and let be a map defined as follows:
Then, is a complete Branciari distance space (see [32]).
Let be a map defined by
Suppose that , where , is a map defined by , and let .
Then, () and () hold, and ϕ is an lsc function.
We now show that C is a σ-Caristi map with lsc
We infer that
Hence,
Consider the following two cases.
First case: Let .
Then, we have that
Second case: Let .
Then, we find that
Hence, C is a σ-Caristi map with The suppositions of Theorem 1 hold, and there are fixed points 1 and 3 on the map C.
Corollary 1.
Let be such that
where , where , is lsc with respect to the first variable. If σ satisfies (), (), (), and (), then C possesses only one fixed point.
Proof.
For each , let and .
Then, is an lsc function. It follows from (21) that for all with ,
By Theorem 1, C possesses a fixed point.
We now show that C possesses only one fixed point.
Let and be such that .
From (21), we acquire that
which leads to a contradiction.
Hence, C possesses only one fixed point. □
Corollary 2.
Let be such that
where is an lsc function with , and is a non-decreasing function. If σ satisfies (), (), (), (), (), and (), where
- ()
- with ,
- ()
- ,
then C possesses only one fixed point.
Proof.
As () holds, it follows from (22) that
which implies
Hence, we find that
Let for all with , where .
Then, is an lsc function with respect to the first variable. Since and is non-decreasing, it follows from and that
By applying Corollary 1, C possesses only one fixed point. □
Remark 6.
Taking in Corollary 1 (or Corollary 2), we have Corollary 2.1 (or Corollary 2.3) of [20].
A map is called a generalized -contraction if it satisfies the following condition.
There exists a function such that
where satisfies
Theorem 2.
Let be a generalized σ-contraction. If σ satisfies (), (), and (), then C possesses only one fixed point.
Proof.
Let , and let
Then, we infer that Otherwise, C possesses a fixed point. So, the proof is finished.
From (23), we find that ,
We now show that is Cauchy.
From (25) and (), we find that
Hence, we acquire
which yields
Thus, is Cauchy. Because B is complete, there is such that
By (), (), and (23), we infer the following inequality,
Applying (24) to the term in (26), we find that
because
Hence, we infer that
By letting in (26) and applying (27),
which yields
Applying Lemma 1, we find that , and C possesses a fixed point.
We now show that C possesses only one fixed point.
Let and be such that .
Then, it follows from (23) that
which leads to a contradiction.
Hence, C possesses only one fixed point. □
Applying Theorem 2 to Newton’s method, we can find the roots of equations.
We recall Newton’s iterative scheme:
where , is a differentiable function, and is an initial point for finding the root of the equation .
Example 3.
Let , and let us apply Theorem 2 to determine the roots of the equation .
We define a map using
Then, we have that for if and only if .
Let and .
We find that for all with ,
By Theorem 2, C has a fixed point . In fact, . Thus, the equation has a solution .
Corollary 3 is obtained by taking in Theorem 2.
Corollary 3.
Let be such that
where satisfies (24).
Then, C possesses only one fixed point.
Remark 7.
Corollary 3 generalizes and extends Theorem 4 [27] to Branciari distance spaces without the continuity of map C and .
Remark 8.
It follows from Remark 2 that our main theorems also hold in complete metric spaces.
4. Corollaries
In this section, we give several fixed-point results and coupled fixed-point results that are obtained by applying the main theorem.
Corollary 4
(Caristi). Let be such that
where is an lsc function.
Then, C possesses a fixed point.
Proof.
Let .
It follows from (28) that for all with
We define by
where , , is an lsc function.
Then, f is an lsc function. From (29), we acquire that for all with ,
By Theorem 1, C possesses a fixed point. □
Recall that a map is called -contraction [28] if it satisfies
where , and is a function.
Jleli and Samet [28] proved that every -contraction possesses only one fixed point whenever is non-decreasing and satisfies () and ().
By applying Corollary 2, we have Theorem 2.1 of [28].
Corollary 5
(Jleli and Samet). Let be a σ-contraction. If σ satisfies (), (), (),(), (), and (), then C possesses only one fixed point.
Proof.
We define by , where .
Then, is an lsc function. By applying (30) and (), we have that for all with ,
By Corollary 2, C possesses only one fixed point. □
Corollary 6.
Let be such that
where . If σ satisfies (), (), (), (), (), and (), then C possesses only one fixed point.
Remark 9.
Let be a Branciari distance space such that ρ is an lsc function with respect to the first variable. If () is satisfied, then the σ-Caristi map is a generalization of a σ-contraction. In fact, if is a σ-contraction, then there is such that
Let .
We find that
which implies
Let and .
Then, we infer that
Hence, C is a σ-Caristi map.
Remark 10.
Inequality (23) of Theorem 2 is a generalization of a σ-contraction whenever () is satisfied. In fact, if C is a σ-contraction, then
Then, we have that
which implies that
Hence, we infer that
Let .
Then, we find that
A map is called a -()-contraction if it satisfies the following condition.
There exists a function such that
where is a continuous and strictly increasing function and is a continuous and non-decreasing function such that if and only if and
Note that is a continuous and strictly increasing function and is a continuous and non-decreasing function such that (32) is satisfied.
Remark 11.
A generalized σ-contraction is a generalization of a σ-()-contraction, where σ is satisfied (). Actually, if is a σ-()-contraction, then from (31), we have that
Hence, and, thus, . It follows from (31) that
Hence, we infer that
Remark 12.
A σ-contraction map is σ-()-contraction, where σ is satisfied (), () and ().
Let be σ-contraction. Then there exists such that, for all
Let and let .
Then, we have that
Hence, C is a σ-()-contraction map.
The following example shows that -Caristi map is not a -contraction map, and it is not a generalized -contraction.
Example 4.
Let and .
Let us define a map by , and let .
Then, we infer that, for all ,
Hence, C is a σ-Caristi map.
We now show that C is not a generalized σ-contraction map.
Suppose that C is a generalized σ-contraction map.
Then, for all with ,
Hence,
which leads to a contradiction, for .
Hence, C is not a generalized σ-contraction.
Example 5.
Let and .
Define a map by , and let .
Thus, C is a generalized σ-contraction map.
We now show that C is not a σ-Caristi map.
We infer that, for all ,
This implies that C is not a σ-Caristi map.
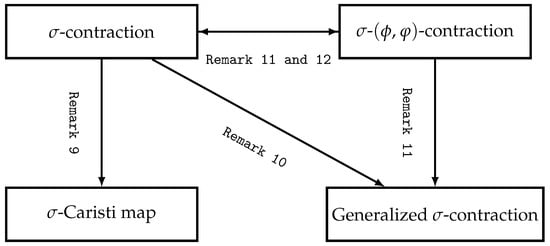
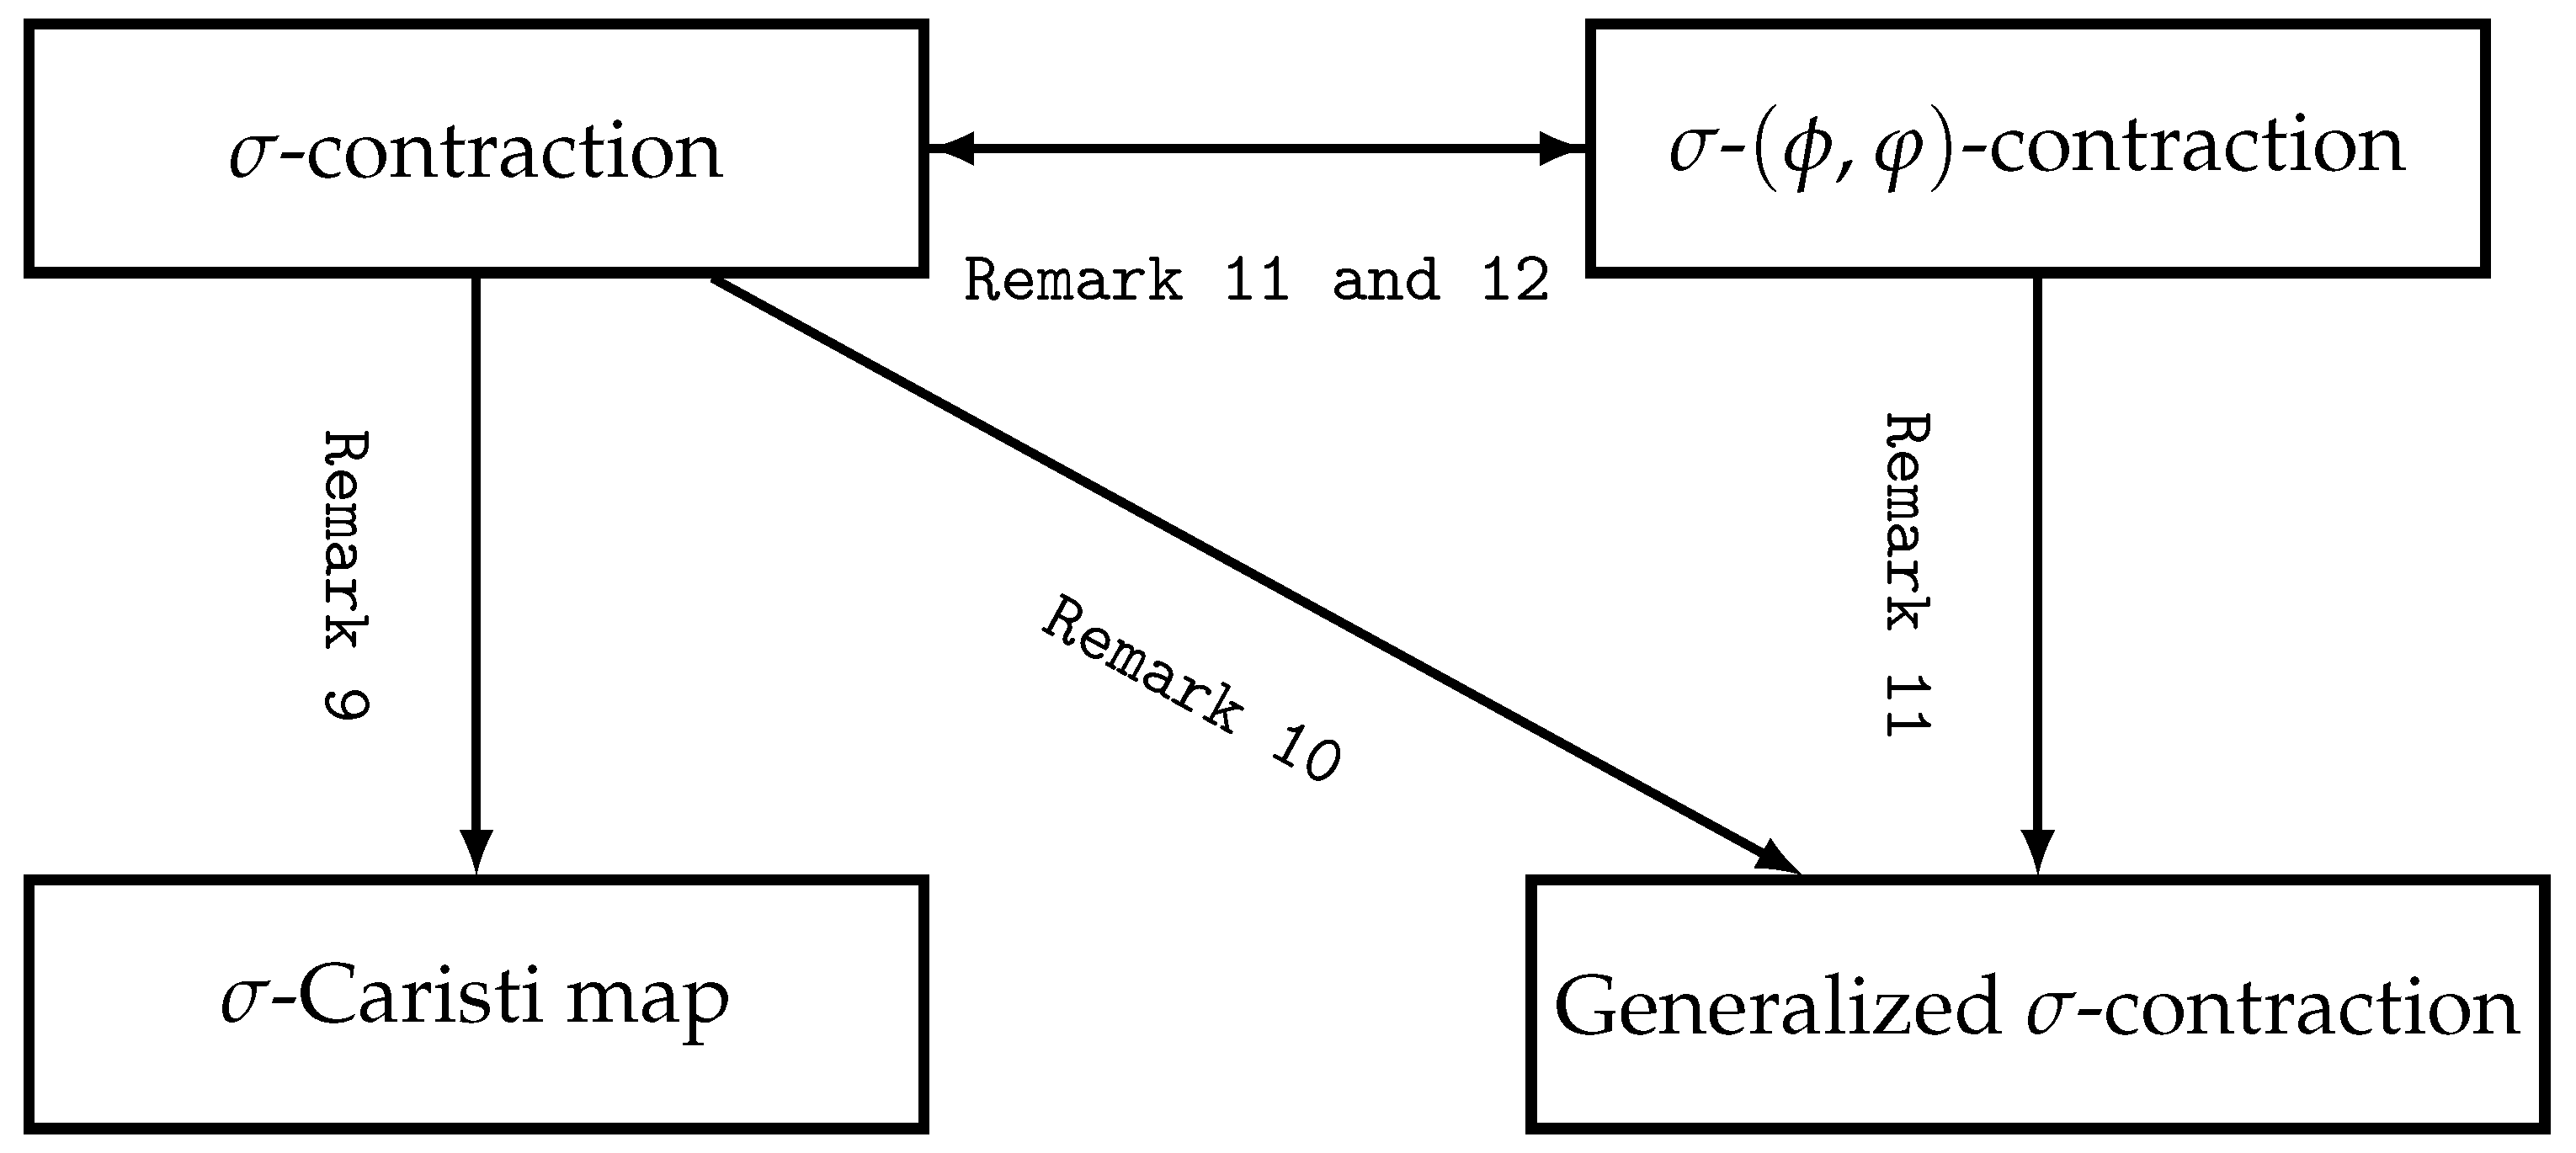
The following figure is derived from the previously mentioned remarks and the above examples. Here, the conditions of applied in each remark are also applied.
The following Figure 1 was created with reference to [42].
Figure 1.
Relationships between different types of contractions.
From the above figure, it can be seen that a -contraction implies a -Caristi mapping, a generalized -contraction, and a -()-contraction. Moreover, a -()-contraction also implies a -contraction. On the other hand, there is no implication relationship between the generalized -contraction and the -Caristi mapping.
By taking in Theorem 1, we acquire Corollary 7.
Corollary 7.
Let be such that
where is an lsc function, .
Then, C possesses a fixed point.
We apply Theorem 1 to prove the existence of coupled fixed points.
Let B be a nonempty set, and let be a map. A point is said to be a coupled fixed point of P if it satisfies
Lemma 3
([43]). Let B be a nonempty set, , and let be a map. We assume that is a map defined by
Then, we find that
Lemma 4.
Let be a complete Branciari distance space. We define by
Then, is a complete Branciari distance space.
Proof.
Let . Then, we have that
Thus, () is satisfied. Obviously, () holds.
We infer that for all and for all distinct points ,
Thus, () holds. Hence, is a Branciari distance space.
We now show that is complete.
Let be a Cauchy sequence, and let be given.
Then, there exists such that for all ,
which implies that
Hence, and are Cauchy sequences in B. From the completeness of B, there exist such that
Hence, there exists such that for all ,
Thus, we have that for all
Hence, we have the desired result. □
Corollary 8.
Let be a complete Branciari distance space. We assume that is a map such that for all with ,
where is an lsc function, . If σ satisfies (), (), (), and (), then P possesses a coupled fixed point.
Proof.
Let Q and be defined as in (31) and (32), respectively.
Then, from (33), we find that for all with ,
By Theorem 1, Q possesses a fixed point. Thus, P possesses a coupled fixed point. □
The following result is obtained using Remark 2.
Corollary 9.
Let be a complete metric space. We assume that is a map such that for all with ,
where is an lsc function, . If σ satisfies (), (), (), and (), then P possesses a coupled fixed point.
Lemma 5.
Let be a complete Branciari distance space. Suppose that σ satisfies (), (), (), and ().
Then, the following assertions are equivalent.
- (i)
- We assume that satisfies the conditionfor all , where .Then, P possesses a unique coupled fixed point.
- (ii)
- We assume that satisfies the conditionfor all , where .Then, C possesses a unique fixed point.
Proof.
Firstly, we show that (i) implies (ii).
Let . Then, for all , it follows from (i) that
Hence, the proof follows from (ii).
Let us define a map using
It follows from (34) that for all ,
which corresponds to (35) with and .
Thus, by (i), P has a unique coupled fixed point . Hence,
From (26), we have
which implies that .
Thus, C has a unique fixed point. □
Corollary 10.
Let be a complete Branciari distance space. Suppose that ρ satisfies (), (), (), and (). We assume that satisfies the condition
for all , where .
Then, P possesses a unique coupled fixed point.
Proof.
By Remark 9 and Theorem 1, C has a fixed point whenever the contractive condition in (36) is satisfied. Obviously, the contractive condition in (36) guarantees the uniqueness of the fixed point. From Lemma 5, we have the desired result. □
Remark 13.
The above result is an extension of Theorem 2.2 from [13], and Lemma 5 and Corollary 10 hold for n-tuple fixed points (see [13]).
5. Applications
The most interesting application of fixed-point theory is its application to function spaces. In this section, we show the existence and uniqueness of solutions to integral equations and differential equations in function spaces.
Let , and let , where . Obviously, is a complete metric space, and hence, it is a complete Branciari distance space.
5.1. Integral Equations
We consider an integral equation of the form
where and are continuous, and is measurable.
Theorem 3.
We assume that for all , and for all , and we suppose that for each and for all ,
Then, the integral Equation (31) has a solution in .
Proof.
We define a map , and suppose that satisfies (), (), (), (), and ().
We infer that for all ,
By taking the supremum and applying (), we find that
which implies that
where .
By Theorem 2, S has a fixed point. Thus, Equation (31) has a solution. □
5.2. Differential Equations
Our objective is to apply Theorem 2 to show the existence of a solution for the following first-order periodic boundary value problem:
where , and is a continuous function.
Let be a Green function defined by
for any positive real number with .
Note that
The preceding problem (34) is equivalent to the integral equation
We define the map by
Then, f is a solution of (34) if and only if it is a fixed point of S. q
Theorem 4.
We assume that for any ,
where .
Then, Equation (34) has a solution.
Proof.
Suppose that satisfies (), (), (), (), and ().
Applying (36), we infer that for any ,
We take the supremum to find that
which implies that
By Theorem 2, S has a fixed point. Hence, Equation (34) has a solution. □
6. Conclusions
In this study, we give the concepts of -Caristi maps and generalized -contraction maps and have related fixed-point results in the setting of complete Branciari distances. By applying the main theorem, we have several corollaries, including Caristi’s fixed-point theorem, Jleli and Samet’s fixed-point theorem, and coupled fixed-point theorem. We give examples to illustrate the sequential topology and the main theorem. In particular, we provide an example of applying the main theorem to Newton’s method to find the roots of an equation. We investigated the relationships among various contraction conditions introduced in this paper. As applications, we solve an integral equation and an ordinary differential equation with the help of our main result.
In the future, based on our main theorem, we will investigate the -Ekland variational principle and the -Takahashi minimization principle, and we will discuss their equivalence with our main theorem.
Funding
This research received no external funding.
Data Availability Statement
Data is contained within the article.
Acknowledgments
The author expresses his gratitude to the reviewers for their careful reading and valuable comments. This research was supported by Hanseo University.
Conflicts of Interest
The author declares that he has no competing interests regarding the publication of this study.
References
- Banch, S. Sur les operations dans les ensembles abstraits et leur applications aux equations integrables. Fundam. Math. 1992, 3, 133–181. [Google Scholar] [CrossRef] [Scilit]
- Edelstein, M. An extension of Banach’s contraction principle. Proc. Am. Math. Soc. 1961, 12, 7–10. [Google Scholar] [CrossRef] [Scilit]
- Jungck, G. Commuting maps and fixed points. Am. Math. Mon. 1976, 83, 261–263. [Google Scholar] [CrossRef] [Scilit]
- Jungck, G. Common fixed points for noncontinuous nonself maps on nonmetric spaces. Far East J. Math. Sci. 1996, 4, 199–215. [Google Scholar]
- Rhoades, B.E. A comparison of various definitions of contractive mappings. Trans. Am. Math. Soc. 1977, 266, 257–290. [Google Scholar] [CrossRef]
- Van An, T.; Van Dung, N.; Kadelburg, Z.; Radenović, S. Various generalizations of metric spaces and fixed point theorems. RACSAM 2015, 109, 175–198. [Google Scholar] [CrossRef] [Scilit]
- Huang, L.G.; Zhang, X. Cone metric spaces and fixed point theorems of contractive mappings. J. Math. Anal. Appl. 2007, 332, 1467–1475. [Google Scholar] [CrossRef] [Scilit]
- Matthews, S.G. Partial metric topology. In Proceedings of 8th Summer Conference on General Topology and Applications. Ann. N. Y. Acad. Sci. 1994, 728, 183–197. [Google Scholar] [CrossRef] [Scilit]
- Amini-Harandi, A. Metric-like spaces, partial metric spaces and fixed points. Fixed Point Theory Appl. 2012, 2012, 204. [Google Scholar] [CrossRef] [Scilit]
- Branciari, A. A fixed point theorem of Banach-Caccioppoli type on a class of generalized metric spaces. Publ. Math. 2000, 5, 31–37. [Google Scholar] [CrossRef] [Scilit]
- Guo, D.; Lakshmikantham, V. Coupled fixed points of nonlinear operators with applications. Nonlinear Anal. Theory Methods Appl. 1987, 11, 623–632. [Google Scholar] [CrossRef] [Scilit]
- Samet, B.; Vetro, C. Coupled fixed point, f-invariant set and fixed point of N-order. Ann. Funct. Anal. 2010, 1, 46–56. [Google Scholar] [CrossRef] [Scilit]
- Rad, G.S.; Shukla, S.; Rahimi, H. Some relations between n-tuple fixed point and fixed point results. RACSAM 2015, 109, 471–481. [Google Scholar]
- Antón-Sancho, Á. Fixed points of principal E6-bundles over a compact algebraic curve. Quaest. Math. 2023, 47, 501–513. [Google Scholar] [CrossRef] [Scilit]
- Antón-Sancho, Á. Fixed points of automorphisms of the vector bundle moduli space over a compact Riemann surface. Mediterr. J. Math. 2024, 21. [Google Scholar] [CrossRef] [Scilit]
- Antón-Sancho, Á. Fixed points of involutions of G-Higgs bundle moduli spaces over a compact Riemann surface with classical complex structure group. Front. Math. 2024, 19, 1025–1039. [Google Scholar] [CrossRef] [Scilit]
- Caristi, J. Fixed point theorems for mappings satisfying inwardness conditions. Trans. Amer. Math. Soc. 1976, 215, 241–251. [Google Scholar] [CrossRef]
- Chaira, K.; Eladraoui, A.; Kabil, M.; Lazaiz, S. Caristi-type fixed point theorem over Száz principle in quasi-metric spaces with a graph. J. Math. 2019, 2019, 8956083. [Google Scholar] [CrossRef] [Scilit]
- Du, W.S. On Caristi type maps and generalized distances with applications. Abst. Appl. Anal. 2013, 2013, 407219. [Google Scholar] [CrossRef] [Scilit]
- Khojasteh, F.; Karapinar, E.; Khandani, H. Some applications of Caristi’s fixed point theorem in metric spaces. Fixed Point Theory Appl. 2016, 2016, 16. [Google Scholar] [CrossRef] [Scilit]
- Suzuki, T. Generalized Caristi’s fixed point theorems by Bae and others. J. Math. Anal. Appl. 2005, 302, 502–508. [Google Scholar] [CrossRef] [Scilit]
- Du, W.S. A direct proof of Caristi’s fixed point theorem. Appl. Math. Sci. 2016, 10, 2289–2294. [Google Scholar] [CrossRef] [Scilit]
- Du, W.S. On Caristi type mappings without lower semicontinuity assumptions. J. Fixed Point Theory Appl. 2015, 17, 733–752. [Google Scholar] [CrossRef] [Scilit]
- Du, W.S. A simple proof of Caristi fixed point theorem without using Zorn’s lemma and transfinite induction. Thai J. Math. 2016, 14, 259–264. [Google Scholar]
- Kozlowski, W. A purely metric proof of the Caristi fixed point theorem. Bull. Aust. Math. Soc. 2017, 95, 333–337. [Google Scholar] [CrossRef] [Scilit]
- Pasicki, L. A short proof of the Caristi theorem. Ann. Soc. Math. Polon. Ser. I Common. Math. 1978, 22, 427–428. [Google Scholar]
- Işiki, H.; Mohammadi, B.; Haddadi, M.R.; Parvaneh, V. On a new generalization of Banach contraction principle with application. Mathematics 2019, 7, 862. [Google Scholar] [CrossRef] [Scilit]
- Jleli, M.; Samet, B. A new generalization of the Banach contraction principle. J. Inequalities Appl. 2014, 2014, 38. [Google Scholar] [CrossRef] [Scilit]
- Ahmad, J.; Al-Mazrooei, A.E.; Cho, Y.J.; Yang, Y.O. Fixed point results for generalized θ-contractions. J. Nonlinear Sci. Appl. 2017, 10, 2350–2358. [Google Scholar] [CrossRef] [Scilit]
- Samet, B. Discussion on “A fixed point theorem of Banach-Caccioppoli type on a class of generalized metric spaces” by A. Branciari. Publ. Math. 2010, 76, 493–494. [Google Scholar] [CrossRef] [Scilit]
- Sarma, I.R.; Rao, J.M.; Rao, S.S. Contractions over generalized metric spaces. J. Nonlinear Sci. Appl. 2009, 2009, 180–182. [Google Scholar] [CrossRef] [Scilit]
- Azam, A.; Arshad, M. Kannan fixed point theorem on generalized metric spaces. J. Nonlinear Sci. Appl. 2008, 1, 45–48. [Google Scholar] [CrossRef] [Scilit]
- Bari, C.D.; Vetro, P. Common fixed points in generalized metric spaces. Appl. Math. Commput. 2012, 218, 7322–7325. [Google Scholar] [CrossRef] [Scilit]
- Cho, S.H. Fixed point theorems for Lγ contractions in Branciari distance spaces. Axioms 2022, 11, 479. [Google Scholar] [CrossRef] [Scilit]
- Cho, S.H. Fixed point theorems for Suzuki type generalized L-contractions in Branciari distance spaces. Adv. Math. Sci. J. 2022, 11, 1173–1190. [Google Scholar] [CrossRef] [Scilit]
- Das, P. A fixed point theorem on a class of generalized metric spaces. Korean J. Math. Sci. 2022, 9, 29–33. [Google Scholar]
- Kirk, W.A. Generalized metrics and Caristi’s theorem. Fixed Point Theory Appl. 2013, 2013, 129. [Google Scholar] [CrossRef] [Scilit]
- Saleh, H.N.; Imdad, M.; Abdeljawad, T.; Arif, M. New contractive mappings and their fixed points in Branciari metric spaces. J. Funct. Spaces 2020, 2020, 9491786. [Google Scholar] [CrossRef] [Scilit]
- Shatanawi, W.; Al-Rawashdeh, A.; Aydi, H.; Nashine, H.K. On a fixed point for generalized contractions in generalized metric spaces. Abstr. Appl. Anal. 2012, 2012, 246085. [Google Scholar] [CrossRef] [Scilit]
- Suzuki, T. Generalized metric spaces Do not have the compatible topology. Abstr. Appl. Anal. 2014, 2014, 458098. [Google Scholar] [CrossRef] [Scilit]
- Jleli, V.; Samet, B. The Kannan’s fixed point theorem in a cone rectangular metric space. J. Nonlinear Sci. Appl. 2009, 2, 161–167. [Google Scholar] [CrossRef] [Scilit]
- Kottwitz, S. Latex Graphics with Tikz: A Practitioner’s Guide to Drawing 2D and 3D Images, Diagrams, Charts, and Plots; Packt Publishing: Birmingham, UK, 2023; pp. 51–150. [Google Scholar]
- Berzing, M.; Karapinar, E. Fixed point results for (αψ, βϕ)-contractive mappings for a generalized altering distance. Fixed Point Theory Appl. 2013, 2013, 205. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the author. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).