


Abstract
We extend the theory of splits in finite metric spaces to infinite ones. Within this more general framework, we investigate the class of spaces having metrics that are integer-valued and totally split-decomposable, as well as the polyhedral complex structure of their injective hulls. For this class, we provide a characterization for the injective hull to be combinatorially equivalent to a CAT(0) cube complex. Intermediate results include the generalization of the decomposition theory introduced by Bandelt and Dress in 1992 as well as results on the tight span of totally split-decomposable metric spaces proved by Huber, Koolen, and Moulton in 2006. Next, using results of Lang from 2013, we obtain proper actions on CAT(0) cube complexes for finitely generated groups endowed with a totally split-decomposable word metric and for which the associated splits satisfy a simple combinatorial property. In the case of Gromov hyperbolic groups, the obtained action is both proper aand co-compact. Finally, we obtain as an application that injective hulls of odd cycles are cell complexes isomorphic to CAT(0) cube complexes.
Keywords:
Buneman complex; CAT(0); cube complex; geometric group theory; graph theory; group action; hyperconvex metric space; hypercube; injective hull; phylogenetics; split system; tight span MSC:
51F30; 20F65; 54E35; 05C12; 05C63; 90C57
1. Introduction
In 1992, Bandelt and Dress (cf. [1]) introduced a decomposition theory for finite metric spaces which is canonical, that is, it is the only one which is in a sense compatible with Isbell’s injective hull (see [2] for a gentle introduction). Our first goal is to extend the canonical decomposition theory to the class of infinite metric spaces with an integer-valued totally split-decomposable metric and possessing an injective hull with the structure of a polyhedral complex. For this class, we then provide necessary and sufficient conditions for the injective hull to be combinatorially equivalent to a CAT(0) cube complex.
This work builds a bridge between different worlds; on the one side, our results extend the work of Bandelt, Dress, and Buneman [3] on finite metric spaces and the correspondence with canonical cell complexes as well as the later extension of those ideas by Huber, Koolen, and Moulton [4,5,6]. Our results show that the decomposition theory can be successfully applied to infinite metric spaces. Moreover, the present work establishes connections with the results of Lang [7], which lie in another area of mathematics dealing with applications to geometric group theory. The group actions that are obtained as a consequence of our results offer new tools in the theory of actions on CAT(0) cube complexes and ultimately aim at contributing to advance the general classification of groups, a long-standing and major goal of mathematical research. Finally, we illustrate our results by providing a concise and elegant characterization of the injective hull of odd cycles. In this way, we recover as a special case results from Suter which were obtained using completely different techniques, namely, Hasse diagrams of Young lattices [8].
The basic definitions of the canonical decomposition theory of Bandelt and Dress do not need to be modified to suit our more general situation. A split (also called cut) of a set X is a pair of non-empty subsets of X such that and , or in other words, . For , we denote by the element of S that contains x. The split (pseudo-)metric associated with S is then a pseudometric on X such that
For a pseudometric d on X, we refer to as a d-split (of X) if the isolation index provided by
satisfies . The pseudometric d is called totally split-decomposable if , where is the set of all d-splits. A split subsystem is called octahedral if and only if there is a partition of X into a disjoint union of six non-empty sets such that consists of the following four splits:
while is called octahedral-free if it does not contain any octahedral split subsystem. Two splits and are said to be compatible if (and thus ), or alternatively if (and thus ).
We provide an outline of the structure of Isbell’s injective hull and present conditions under which it has the structure of a polyhedral complex, following [7]. Given a pseudometric space , let us consider the vector space of real-valued functions on X and . We refer to as extremal if there is no in distinct from f. The set of extremal functions is equivalently provided by
In order to be able to describe the structure of further, it is possible to assign the undirected graph with vertex set X and edge set to every , allowing self-loops which correspond to zeros of f. Furthermore, we let . Note that if , then the graph has no isolated vertices (although it may be disconnected). A set A of unordered pairs of (possibly equal) points in X is called admissible if there exists an with , and we denote by the collection of admissible sets. To every , we associate the affine subspace of provided by . We define the rank of A by , which is provided by the number of bipartite components or even A-components of . As an example, if denotes the distance function to i.e., , then . We also have another example to show that the rank can be infinite; indeed, if denotes the unit circle endowed with the intrinsic geodesic metric and if denotes the function that is constantly equal to , then it is possible to verify that . See [9] for a discussion of related examples.
If is a finite metric space, then is a finite polyhedral complex; if is infinite, then we say that satisfies the local rank condition (LRC) if and only if for every there exist such that for all with we have . Recall (cf. [7], Theorem 4.5) that if is a metric space with an integer-valued metric and satisfying the (LRC), then ; in this case, let . Then, the family defines a polyhedral structure on ; in particular, is a face of if and only if . This defines a canonical locally finite dimensional polyhedral structure on . In the case where d is totally split-decomposable, our goal is to provide necessary and sufficient conditions ensuring that is combinatorially equivalent to a cube complex. Accordingly, we have the following theorem.
Theorem 1.
Let be a metric space with an integer-valued totally split-decomposable metric satisfying the local rank condition and let be the set of all d-splits; then, the following are equivalent:
- (i)
- does not contain any octahedral split subsystem , satisfying the requirement that for every there is such that S and are compatible.
- (ii)
- Each cell of is a parallelotope.
- If (i) or equivalently (ii) in Theorem 1 holds, then there is a CAT(0) cube complex and a canonical bijective cell complex isomorphism mapping cells affinely to cells.
For general facts regarding injective hulls, we refer to [7]. Injective hulls can be characterized in several different ways. In the sequelae, the injective hull refers to Isbell’s injective hull construction . The difference between two elements of has a finite -norm, and is endowed with the metric . It is easy to see that for , if , then ; hence, if is a pseudometric space and is the associated metric space obtained by collapsing every maximal set of diameter zero to a single point, then and are isometric. Accordingly, statements involving the injective hull will be stated for metric spaces instead of for pseudometric spaces.
We use the word parallelotope for a Minkowski sum of a finite collection of linearly independent closed segments (for instance, see [10]). Whenever condition (i) in Theorem 1 holds, we say that the family of all d-splits of X has no compatibly octahedral decomposition. If the diameters of the cells of are uniformly bounded, then in Theorem 1 can be chosen to be bi-Lipschitz. For a metric space , let denote the interval between x and y, and for let the cone determined by the directed pair be provided by . For a subset B of X, we denote by the set of all pointed cones with and . In addition, is called discretely geodesic if the metric is integer-valued and for every pair of points there exists an isometric embedding such that and . Moreover, we say that a discretely geodesic metric space X has β-stable intervals for some constant if, for every triple of points such that , we have , where denotes the Hausdorff distance in X.
Among its other features, the injective hull has applications to geometric group theory. Let be a finitely generated group and G a finite generating set, and let be equipped with the word metric with respect to the alphabet . Note that the metric is integer-valued.
Theorem 2.
Let be a metric space where Γ is a finitely generated group and G a finite generating set, and let denote the word metric defined on Γ with respect to the alphabet . Assume that is totally split-decomposable and that (i) or equivalently (ii) in Theorem 1 holds. Then, the following hold:
- (i)
- If has β-stable intervals, then there is a proper action of Γ (a CAT(0) cube complex ) provided by
- (ii)
- If is δ-hyperbolic, then the action of Γ on is also co-compact.
To prove Theorem 1, and consequently Theorem 2, we need to decompose any pseudometric d on a set X in a way that is coherent with the structure of . The isolation index of a pair of non-empty subsets with respect to a pseudometric d on X is the non-negative number (equivalently , or simply ) provided by (1). We then refer to a pseudometric on X as split-prime if for any split S of X. Note that per Lemma 1, for any integer-valued pseudometric there are only finitely many d-splits separating any pair of points.
Theorem 3.
Let be a pseudometric space with an integer-valued pseudometric, let be the set of all splits of X, and let be the set all d-splits. Letting
is a pseudometric such that for every split we have ; in particular, there is a split-prime pseudometric such that
The decomposition provided by Theorem 3 can be characterized uniquely in a corollary to Theorem 6 which relates to the structure of general cellular graphs; see [11] (Section 8.3).
Corollary 1.
Let be a metric space with an integer-valued metric satisfying the LRC. Let be the family of all d-splits of X such that , and let for every . Then, setting , we have
Moreover, for any split of X and any such that , if , then the following hold:
- (i)
- S is a d-split of X.
- (ii)
- .
We conclude with a discussion of the future research directions that can build on the present work. The results presented here echo the discussion in [12], where interest in infinite metric spaces and CAT(0) complexes were highlighted. The conclusions of our work suggest that other ideas which are originally developed for finite metric spaces, for instance in phylogenetics, can be successfully generalized to the infinite case. Subsequently, such correspondence can be leveraged to infer results about abstract metric spaces in order to provide links to other areas of mathematics with a novel perspective, such as geometric group theory. Finally, splits in metric spaces are not only relevant in the case of tight spans; there has also been recent work on links with Vietoris–Rips complexes [13] with applications to topological data analysis (TDA), which is an exciting direction for further research.
2. Decomposition Theory
It is easy to see that as defined at the beginning of the introduction is a subset of . Note that a function belongs to if and only if
where denotes the distance function to , i.e., . The metric on is thus well-defined and is equipped with the induced metric. We have the canonical isometric mapping , provided by . Let be any pseudometric space. A partial split of X is a pair of non-empty subsets of X such that . If also holds, then is a split of X. A partial d-split is a partial split for which . Note now that if is a pseudometric space with integer-valued pseudometric, then for any split S we have
The proof of the next lemma is very similar to the proof of its finite analogue, except that we cannot use induction on the set of all d-splits [14] (IV.2 Theorem 2.3). Instead, we use the fact that for every there are and , such that (if , we still use to denote ). Moreover, if satisfies , then we have .
Theorem 4.
Let be a pseudometric space such that, for every , there are only finitely many distinct d-splits S satisfying . Moreover, let be a partial d-split. Then,
The next lemma enables us to use several arguments of [1] by examining the pointwise behavior of pseudometrics. The approach of [15], which generalizes [1], has a global nature which causes obstructions to any direct adaptation to the case with .
Lemma 1.
Let be a pseudometric space with an integer-valued pseudometric. For every , there are at most distinct d-splits S satisfying .
Proof.
Assume by contradiction that we can find distinct d-splits such that . For every , choose such that either or . Furthermore, setting , we have if ; hence
and per the special case ([1], Theorem 1) of Theorem 4 applied to the partial split and of the finite set Z, the right-hand side is less than or equal to , which is a contradiction. This concludes the proof. □
It is possible to prove the next lemma by a direct modification of ([1], Theorem 2).
Lemma 2.
Let be a pseudometric space with an integer-valued pseudometric. Let be the set of all d-splits of X and let be any finite subset. If for every and for every other split, then is a pseudometric such that for every split S of X we have
The next definition is taken from [1], where it is introduced for finite metric spaces. The same definition extends to the infinite case without modification.
Definition 1.
We refer to a collection of splits of a set X as weakly compatible if there are no four points and three splits such that for any one has .
It follows immediately from the above definition that the collection of all d-splits with respect to any pseudometric d on X is weakly compatible. This is part of the next theorem.
Theorem 5.
Let denote any pseudometric space with an integer-valued metric; then, the d-splits of X are weakly compatible. Conversely, let denote any collection of weakly compatible splits of X and choose for each some such that
It follows that is the set of all d-splits and that for each , the isolation index coincides with .
The proof of Theorem 5 is a close analogue to the proof of ([1], Theorem 3); see [14]. The assumptions in the next lemma ensure that is a polyhedral complex. We denote by the set of vertices of the polyhedral complex ; equivalently, it is the set of all functions such that . The idea of considering this set of functions is inspired by [15] (Lemma 2.2). Both Lemma 5 and Theorem 6 highlight differences that arise when extending the theory of finite metric spaces to infinite ones.
Lemma 3.
Let be a metric space with an integer-valued metric satisfying the LRC, and let . Let be any finite subset of the set of all d-splits of X. If we pick for every , then we have functions such that
Proof.
Let , where is any finite subset . Note that means that f is a vertex of the polyhedral complex , which is equivalent to by definition. Thus, is in particular not bipartite, meaning that there are such that and either or . Assume without loss of generality that . Note also that if there are such that we have , then , which contradicts our assumption. Hence, for any , we have . Now, setting
it readily follows that and satisfy . Furthermore, note that if , then either or and . In both cases, it is evident that (noting that refers to those pairs satisfying ). Thus,
hence, in particular, . For , we can proceed as above and find such that . Now, by Theorem 3, it follows that . This implies that for any , we have . Now, setting
we obtain , as before. Per (7), it follows that . It then follows as a result that
where . Proceeding by induction, we get the desired result. □
For an infinite split system , we generally have and cannot replace by .
Theorem 6.
Let be a metric space with an integer-valued metric satisfying the LRC. Let be the family of all d-splits of X such that and let for every , setting . Then,
Proof.
Let be the set of all d-splits and let . As in the proof of Lemma 3, means that f is a vertex of the polyhedral complex , which by definition is equivalent to . Thus, is not bipartite, which means that there are such that . Without loss of generality, we assume that . Then, for any , we have . Now, setting
we first show that for every , we have . Note that for every there exists such that . Furthermore, we have
Because , we deduce that the set
is finite. Moreover, for every , because , by definition we have and . It then follows that as well as that
For , it now remains to show that . For every , there are such that . Because for every we have , it follows that , where . By Lemma 3 and setting , it follows that
and thus that . This shows that . Now, using the fact that satisfies the LRC, we can consider for each cell of all finite convex combinations of its vertices, and by convexity of and , for every we can deduce that . Finally, adding on both sides and intersecting with , we get
Because the other inclusion is easy to see, we obtain the desired result. □
Hence, we obtain the first part of the statement of Corollary 1. By virtue of Remark 1 below, the proof of the second part of the statement of the corollary is similar to the proof of the corresponding assertion for the set in ([1], (Theorem 7).
Remark 1.
Properties (4) and (8) are equivalent. It is shown in the proof of Theorem 6 that (4) implies (8). To see that the other implication holds, remember that by [7] (Proposition 3.1) there is a 1-Lipschitz map such that one has for every . From (4), we obtain a decomposition of g as . Moreover, ; hence,
which is the desired result.
3. The Buneman Complex and Related Topics
If is a split system on a set X and is any map , then the pair is called a split system pair (of X). If is weakly compatible, as in Definition 1, then is called a weakly compatible split system pair. Now, let be a weakly compatible split system on a pseudometric space with an integer-valued pseudometric and assume that . Per Theorem 5, is the set of all d-splits of X; thus, d totally split-decomposable. The weakly compatible split system pair is called the split system pair associated with . Unless otherwise stated, this is the split system pair that we refer to in the rest of the discussion when considering a totally split-decomposable pseudometric space . We want to stress that the sets and X are generally infinite.
Definition 2.
We refer to as acell complexif K is a subset of a real vector space endowed with a family of convex subsets of such that the collection verifies that and for any . The sets are called the cells of , and the dimension of is the dimension of its affine hull, which in general is infinite.
Let be any split system pair on a set X, and consider
For a map , we can write . If , then we denote the complement by . For a given , we denote the associated split by . We define the following hypercube:
which is in general infinitely dimensional. Here, has a natural cell complex structure; cells are sets of the form
where . The cells of are (possibly) infinite-dimensional hypercubes. The Buneman complex is the subcomplex of provided by
Next, we define
It is easy to see that is a subcomplex of , as in the finite case ([16], Section 4). For , the map is defined as
Furthermore, let be provided by
The map is provided by , where for . As a direct application of the above definitions, we obtain the following lemma.
Lemma 4.
Let be a split system pair on a set X and assume that defines a pseudometric on X. Then, the following hold:
- (i)
- For every , we have .
- (ii)
- For every , we have .
- (iii)
- , where each side might be infinite.
Under the assumptions of Lemma 4, for and , let if and if . For a further and , a direct calculation shows that
and that equality holds if .
Lemma 5.
Let be a split system pair on a set X and assume that defines a pseudometric on X. Then, for every , the following are equivalent:
- (i)
- .
- (ii)
- .
Proof.
Consider . We first show that implies . Let , and assume that . For , we have ; thus, . By our contradiction assumption, there is such that for every we have , where the left-hand side is possibly infinite. Because , equality holds in (10); hence, there is such that and . Therefore, where . Moreover, . It follows that . This shows that implies .
To show the other implication, assume that . For every , there is such that . Per (10), we have the following for any :
Note that for any , there exists by definition as well as such that . Now, if and assuming by contradiction that , we can pick an arbitrary . Then, for every we have , and thus . It is now clear that the existence of z contradicts (11). Indeed, for any , there is such that , and hence
However,
and y can be chosen so that . Thus, by (11) and (12), we have which is a contradiction to (13). This finishes the proof. □
Using Corollary 1, Lemma 5 and proceeding similarly to ([17], Theorem 3.1), we can immediately deduce the next lemma; see [14] (IV.3, 3.4 Lemma). Note that under the assumptions of Lemma 6, we have .
Lemma 6.
Let be a totally split-decomposable metric space with an integer-valued metric satisfying the LRC. Then, is surjective.
For a map , let . Define for a cell of and the map provided by
Note that if and , then . Therefore, ; hence, by (9).
Definition 3.
Let be an isometric map of pseudometric spaces. We say that is X-gated (for i and with respect to ) if and only if for every there is such that for every we have .
From Lemma 5, it follows that the restriction of to defines a metric. The proof of the next lemma proceeds as the proof of ([4], Lemma 3.1); see [14] (IV.3, 3.6 Lemma).
Lemma 7.
Let be a split system pair on a set X and assume that defines a pseudometric on X. Then, every cell of is X-gated with respect to the restriction of to .
By virtue of Lemma 5, we also obtain the next lemma.
Lemma 8.
Let be a split system pair on a set X and assume that defines a pseudometric on X. Then, for every , the split system is antipodal, which means that for any there is such that
For , if , then x and y satisfy (14).
Proof.
Let . By Lemma 5, we have . Thus, for any , there is such that , which can be rewritten as
It is easy to see that for every , we have
which together with (15) implies
Assume now that there is such that ; then, per (16) we have , which implies and thus , which is a contradiction. This finishes the proof. □
By Lemma 7, every cell of is X-gated. Let denote the set of all X-gates of endowed with the restriction of . A pseudometric space is called antipodal if there exists an involution such that for every one has . With Lemma 8, the proof of the next lemma is easily seen to be similar to that of ([4] Lemma 4.2); see [14] (IV.3, 3.8 Lemma).
Lemma 9.
Let be a split system pair on a set X and assume that defines a pseudometric on X. Then, for every cell of , the metric space is antipodal.
For , we know from Lemma 5 that . Recalling from the introduction that and setting , we let . If has an integer-valued metric and satisfies the LRC, is a cell complex in which all cells are of this form.
Lemma 10.
Let be a split system pair on a set X and assume that defines a pseudometric on X. Then, for every cell of , one has .
Lemma 10 (see [14], IV.3, 3.9 Lemma) follows easily from a direct computation, i.e., it is possible to show that for each such that we have the following equality for every :
which implies .
Remark 2.
For , let , where . Set and , then:
- (i)
- Assume that has an integer-valued metric, is totally split-decomposable, and satisfies the LRC. In the proof Lemma 11 below, we only require that every cell of can be written aswhere for each one has . To see that this holds, note first that per Theorem 6; then, it is easy to see from the definition of the sets and the fact that we have a decomposition with for every that where and . In addition, for every , we have for each satisfying .
- (ii)
- It is not difficult to see that if is as in (i) and if every cell of is a combinatorial hypercube, then the representation in (18) verifiesThis can easily be proved by induction using the fact that every cell can be written as the Minkowski sum of all its edges incident to a single vertex. If is as usual and if , then it is easy to see that ; in particular, .
- (iii)
- For , as in (ii), let us define by the assignment , where is defined for every as well as for arbitrarily chosen and by settingThis definition depends on a choice of a representation for f, and in general this choice is not unique. We denote by an arbitrarily chosen element of such that and that is maximal among the elements of . Furthermore, note that we always have . It follows that κ is surjective. In general, ; however, if every cell of is a combinatorial hypercube, then the map defines a bijection as well as an isomorphism of cell complexes.
The proof of the next lemma is an easy consequence of Remark 2; see [14] (IV.3, 3.15 Lemma).
Lemma 11.
Let be a totally split-decomposable metric space with an integer-valued metric which satisfies the LRC. For every cell of , if and are defined as in (iii) of Remark 2, then one has .
Recall that there is a canonical isometric embedding provided by in which is endowed with the metric . Assume that satisfies the assumptions of Lemma 11. We say that is cell-decomposable if every cell C of is X-gated (cf. Definition 3). Now, a direct computation shows that is a gate for in . Thus, we have the following lemma; see also [14] (IV.3, 3.16 Lemma).
Lemma 12.
Let be a totally split-decomposable metric space with an integer-valued metric satisfying the LRC. Then, is cell-decomposable.
Let denote the set of all X-gates of endowed with the restriction of the metric . We denote by the gate of in . It is easy to see that the proof of ([6], Theorem 1.1) directly generalizes to the case where as long as and using an extension of the Mazur-Ulam Theorem [18]. Hence, we have the next theorem; see [14] (IV.3, 3.17 Theorem).
Theorem 7.
Let be a metric space with an integer-valued metric satisfying the LRC. If is such that is X-gated, then the following hold:
- (i)
- is a finite antipodal metric space.
- (ii)
- The map provided byis a bijective isometry as well as an isomorphism of polytopes.
Furthermore, it is easy to see that . The proof of the next lemma is immediate; see [14] (IV.3, 3.18 Lemma).
Lemma 13.
Let be a map of metric spaces such that the following hold:
- (i)
- κ is 1-Lipschitz.
- (ii)
- κ is surjective.
- (iii)
- is an antipodal metric space.
- (iv)
- For each , there is antipodal to x such that .
- Then, it follows that κ is an isometry.
The next lemma follows immediately from Lemma 13; see [14] (IV.3, 3.19 Lemma).
Lemma 14.
Let be a totally split-decomposable metric space with an integer-valued metric satisfying the LRC. Let be any positive-dimensional cell of and let and be defined as in (iii) of Remark 2. Then, the map is an isometry.
For arbitrarily chosen , it follows from the definitions of and that we have
where is weakly compatible. It follows by Theorem 5 that
4. The CAT(0) Link Condition for the Buneman Complex and the Cubical Injective Hull
The complex displays some similarities with the CAT(0) cube complex that is constructed in [19] and denoted by X. The next definition is a combinatorial characterization of the local CAT(0) condition for cube complexes (cf. [20]). We stress again that, unless otherwise stated, sets and complexes are in general infinite; in particular, and X are in general infinite. Cell complexes are defined in Definition 2.
Definition 4.
A cell complex with finite-dimensional cells that are combinatorial hypercubes is said to satisfy the CAT(0) link condition if, for every set of seven cells of such that the following hold:
- (i)
- ,
- (ii)
- ,
- (iii)
- , and for each both and ,
- there exists a cell of such that and .
The next lemma follows directly from the definitions; see [14] (IV.4, 4.2 Lemma).
Lemma 15.
Let be a split system pair on a set X. Then, the Buneman complex satisfies the CAT(0) link condition.
A split system is called antipodal whenever, for every , there is such that for every one has . As a preliminary to the proof of Theorem 8, we require the following lemma (cf. [14], IV.4, 4.3 Lemma).
Lemma 16.
Let be a split system on a set X. Then, the following hold:
- (i)
- Assume that is a weakly compatible split system and assume that the split system is antipodal for all . Then, is also antipodal.
- (ii)
- Let be a totally split-decomposable metric space (hence, in particular, is weakly compatible). Let be such that, for the split systems provided in (i), one has . Then, for every it is possible to find such that the following hold:
- (a)
- For some , we have .
- (b)
- For every , we have .
It is easy to prove (i) above by contradiction, and (ii) follows from (i) and the last statement of Lemma 8. Thus, we have now the tools at hand to prove the next theorem.
Theorem 8.
Let be a metric space with an integer-valued totally split-decomposable metric satisfying the LRC such that each cell of is a combinatorial hypercube. Then, satisfies the CAT(0) link condition.
Proof of Theorem 8.
Let be cells as in Definition 4 and with . Per Lemma 15, there is such that and as in Lemma 16. Let be chosen arbitrarily; per (ii) in Lemma 16, there is such that for every we have , and without loss of generality . By a direct computation, it can be shown that
similarly to (17). It follows that
Because there is such an for any , it follows that . Moreover, from the definition of , we have
where the last inclusion follows from Lemma 10. Now, because is a hypercube, this proves that satisfies the CAT(0) link condition and concludes the proof. □
For any metric space , the underlying graph of is the graph , where if and only if for any . Furthermore, let denote the six-cycle metric graph and let denote the complete graph on six vertices with three disjoint edges taken away (i.e., the 1-skeleton of the octahedron).
Remark 3.
Note that if is an antipodal split system on , then for any , if , it follows that . Indeed, if , there is a subsystem of pairwise different splits such that . Now, we have such that , which implies that . An octahedral split system is an example of antipodal split system.
We can now proceed to prove the results described in the introduction.
Proof of Theorem 1.
The second part of Theorem 1, that is, the existence of and , follows immediately from Theorem 8. Indeed, Theorem 8 implies that if we re-metrize by identifying each cell (which is a parallelotope by the first part of Theorem 1) with a corresponding unit hypercube (of same dimension) endowed with the Euclidean metric, while considering the induced length metric, we obtain a complex which satisfies the CAT(0) link condition. Because satisfies the LRC, it follows that is complete and locally CAT(0) (analogous to I.7.13 Theorem and II.5.2 Theorem in [21]). Per the LRC, it also follows that is locally bi-Lipschitz equivalent to ; therefore, the topology induced by the length metric on is the same as the topology on , meaning that is contractible as well. By the Cartan–Hadamard Theorem, it follows that is globally CAT(0).
We now prove the first part of Theorem 1. As an introductory remark, note that per Lemma 9, Lemma 14, and (22) it follows that is an antipodal totally split-decomposable metric space with elements. By Theorem 7, is combinatorially equivalent to , which is per [6] (Theorem 1.2) an n-dimensional combinatorial hypercube if . Moreover, if , then is clearly a combinatorial hypercube as well. Now, assume that . Because is antipodal, it follows by [5] (Corollary 3.3) that is either or . If , then by [6] (Theorem 1.2 (a)), is a three-dimensional combinatorial hypercube.
Assume now that is a combinatorial rhombic dodecahedron, i.e., (ii) in Theorem 1 does not hold; then, , and it follows by the proof of [5] (Theorem 5.1, Case 2) that where is weakly compatible and that the coefficients are all positive. Moreover, per (21) and Lemma 14, we have , where is weakly compatible and consists of d-splits of X. Note that the metric on induces a pseudometric on X by setting . It follows by Theorem 5 and approximation by rescalings of integer-valued pseudometrics that , which has the form provided in (2).
From our introductory remark and since we have assumed that is a combinatorial rhombic dodecahedron, then must be a maximal cell (in dimensions higher than three, a cell must be a hypercube, and the same holds for all of its faces). Because our assumptions imply that and is a three dimensional maximal cell, it follows by application of Zorn’s lemma that the graph consists of three bipartite connected components. In fact, one can prove that for maximal cells those components are complete bipartite; this observation is due to Urs Lang (see [14], V.1, 1.2 Theorem). The respective partitions of the components are provided by , and (this is the only possibility, since if , then for every ). For each , there is such that by bipartiteness (say, ). It follows from (10) that , where and . Hence, , and thus for every further one has . By bipartite completeness of , this implies that there are such that , which is equivalent to and being compatible (i.e., ). It follows that (i) in Theorem 1 does not hold.
Conversely, assume that (i) does not hold, and hence there exists such a split subsystem with the properties stated in (i). Define such that and consists of four splits, as provided in (2), and is a converse to (i). We can choose such that for any we additionally have for , and accordingly . By Remark 3, we have . Thus, consists of the three complete bipartite connected components which implies that . It is easy to see that we have the decomposition , so that for we have
and holds for as defined in (iii) of Remark 2. From (i) of Remark 2, we have that and . However, (25) shows that , since . It follows that , and we can thus set . We then have , and with Lemma 14 we obtain that is a combinatorial rhombic dodecahedron. Thus, (ii) in Theorem 1 does not hold either. This finishes the proof. □
We conclude now with the proof of another theorem.
Proof of Theorem 2.
Let be a finitely generated group with finite generating set G, and consider the associated word metric with respect to the alphabet . Recall that . Recall that for , the cone determined by the directed pair is provided by and that for a subset B of , denotes the set of all pointed cones with and . Because has -stable intervals, [7] (Theorem 4.5 and Proposition 5.12) provide that and that for any and any , every with satisfies . Therefore, satisfies the local rank condition. It is implied by ([7], Theorem 1.1) that is proper and has the structure of a polyhedral complex. The isometric action of on provided by consequently induces a proper action by cell isometries of on , provided by as a consequence of ([7], Theorem 1.4). Because is assumed to be totally split-decomposable and satisfies the combinatorial condition (i) in Theorem 1, it follows that the injective hull is combinatorially equivalent to a CAT(0) cube complex via a canonical cell-wise affine isomorphism . This concludes the proof of (i).
Now, regarding (ii), if is -hyperbolic (in particular, if it has -stable intervals), then has only finitely many isometry types of cells, and the action is co-compact by virtue of ([7], Theorem 1.4). □
5. Examples
We conclude with two examples to illustrate our results and concepts.
Example 1.
Let denote an infinite connected bipartite -graph as defined in [11], endowed with the shortest-path metric. From the finite case, it readily follows that d is totally split-decomposable, that is, , where every S is an alternating split on X (cf. [11]). Furthermore, satisfies the LRC. This can be seen by noting that the isometric cycles in are gated (cf. [11], Theorem 8.7), it follows that has 1-stable intervals; thus, by the proof of ([7], Theorem 1.1), we obtain the desired result. It is easy to see that by bipartiteness, the set of d-splits is octahedral-free. Hence, satisfies all assumptions of Theorem 1. Examples of such infinite bipartite -graphs are provided for , for σ any element of the symmetric group , and for by the Cayley graph of Coxeter groups of the form
The restriction on the number of relations ensures that the Cayley graph is planar, ensures that the degree is at least four, and the condition for every i ensures that each face contains at least four vertices.
Before moving on to the last and main example, we note that two splits and of X are called incompatible if . A split system is then called incompatible if any pair of splits in is incompatible.
Example 2.
For , let
The graph is the odd cycle with vertices, and we endow it with the shortest path metric d. We now provide an explicit description of the injective hull . It can be easily verified that , where is the set of all d-splits of X; hence, is constantly equal to . We have , where the split is provided by for , with the indices taken modulo . Now, it is not difficult to prove that the assumptions of Theorem 1 are fulfilled for . Because we are in the case of a finite metric space, the LRC is trivially satisfied. Moreover, d is totally split-decomposable, and it is not difficult to see that is octahedral-free. Thus, (i) in Theorem 1 holds.
Because is finite, we have (cf. [22], Proposition 7.3), and by (iii) in Remark 2, the map is in particular an isomorphism of cell complexes. Thus, the family of maximal cells of is in bijection with the family of maximal cells of , which in turn bijectively corresponds with the family of maximal incompatible split subsystems . To compute , it is easier to describe the split system in a different way. For , we assign to every edge of the pair of splits and which cut the edge (i.e., and ) and which are determined by the requirements and along with and ; moreover, . We divide the family of maximal incompatible split subsystems of into three subfamilies
so that for with we have three cases for each of the three subsets of .
First, if and only if . In this case, we have
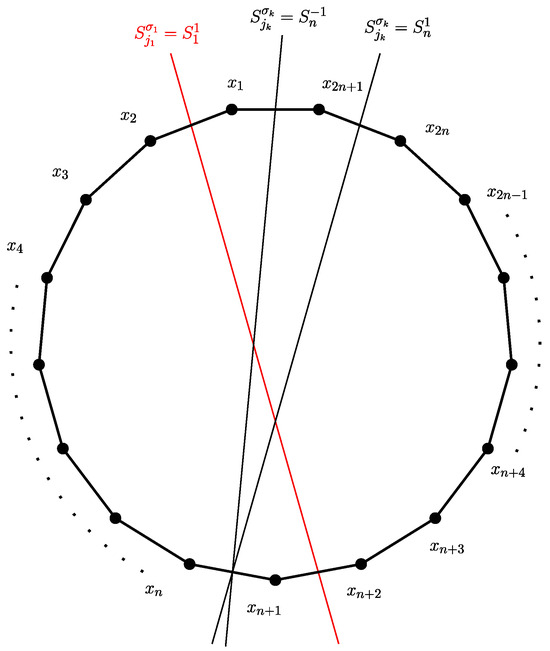
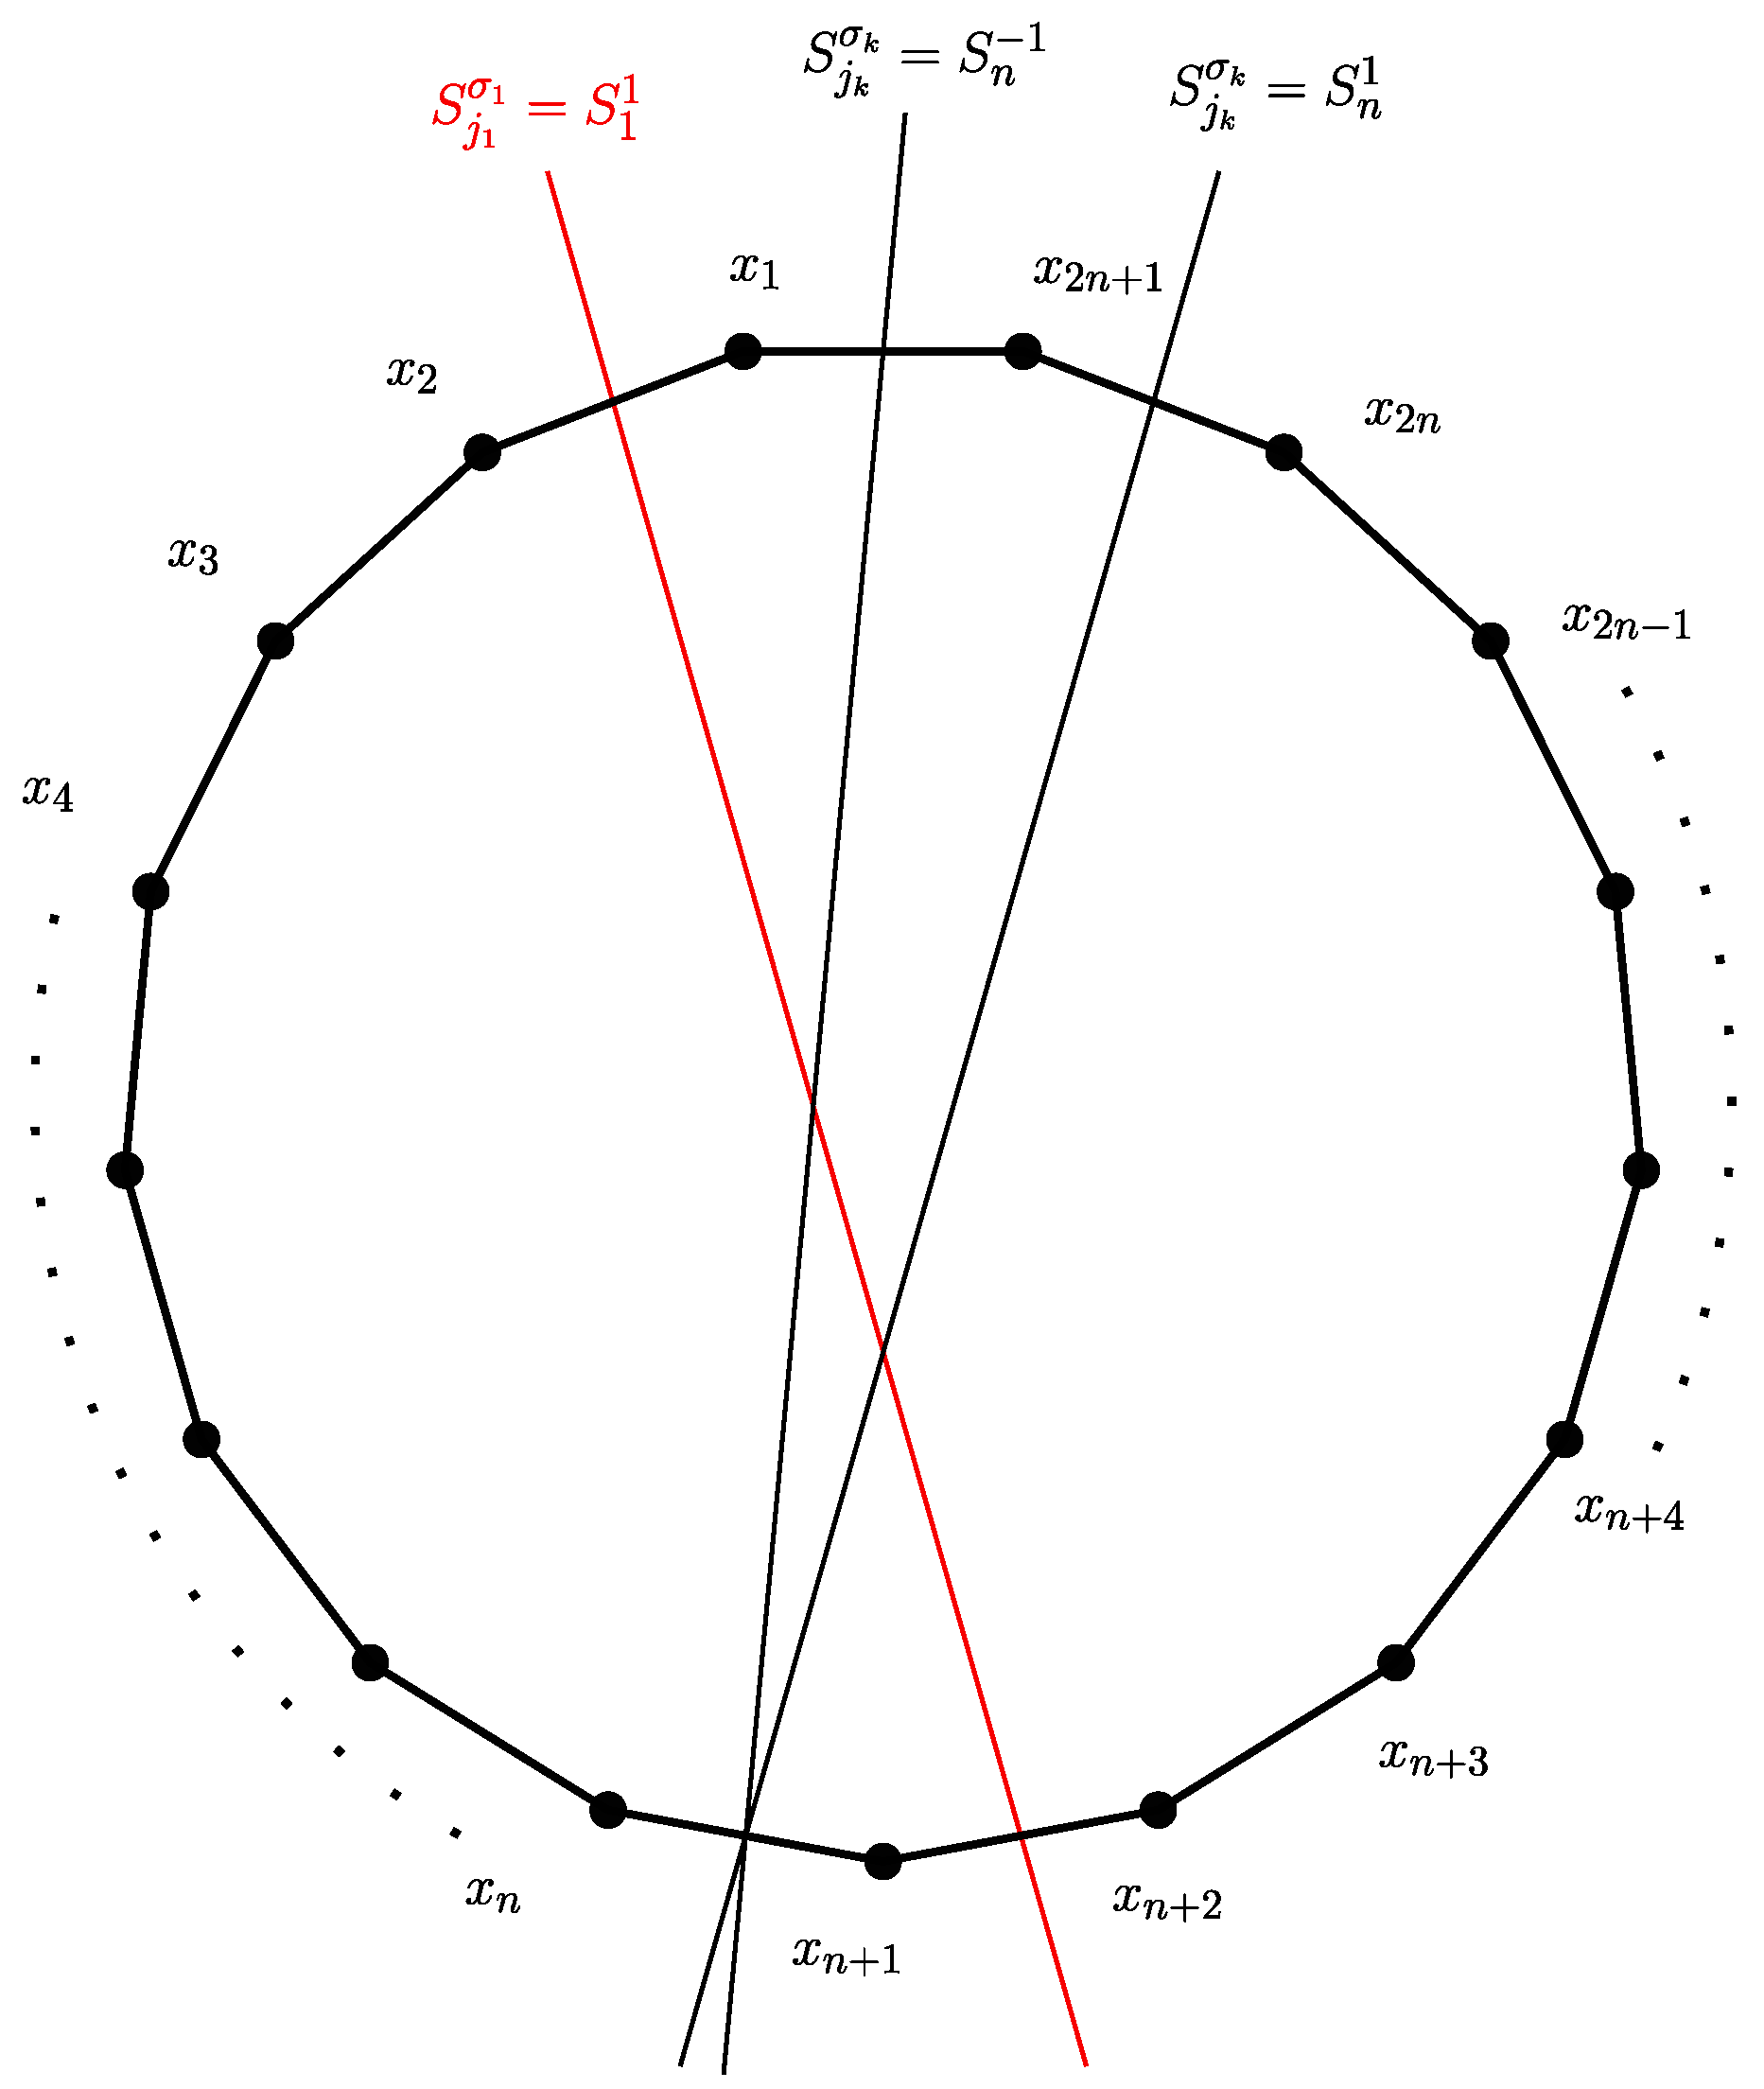
where stands for the case in which and for the case in which . The notation refers to the fact that and (i.e., starting with and going counterclockwise, we count points until we hit the line representing ; similarly, when starting with , we count points until we hit the line representing ). This case is depicted in Figure 1.
Figure 1.
The integer corresponds to the count of maximal incompatible split systems with and , while is the count of splits with and .
Second, if and only if . In this case, we have
where by symmetry stands for the case in which and for the case in which .
Third, if and only if . In this case, we have
and by symmetry stands for the case in which .
Summing up, we obtain the formula
and it is easy to see that we also have the following recurrence relations and along with the initial conditions , , and . The first values of for are listed in the following table.
| n | 1 | 2 | 3 | 4 | 5 | 6 | 7 | 8 | 9 | 10 |
| 3 | 5 | 7 | 12 | 22 | 39 | 68 | 119 | 209 | 367 |
The numbers can also be proved (see e.g., [23]) to correspond to the coefficient of in the power series expansion in a neighborhood of the origin of the analytic function
Funding
This research was funded in part by the Swiss National Science Foundation grant number 153309.
Data Availability Statement
Data are contained within the article.
Acknowledgments
I am very grateful to Urs Lang for numerous stimulating conversations about the topics of this work.
Conflicts of Interest
The author declares no conflicts of interest.
References
- Bandelt, H.-J.; Dress, A.W.M. A Canonical Decomposition Theory for Metrics on a Finite Set. Adv. Math. 1992, 92, 47–105. [Google Scholar] [CrossRef] [Scilit]
- Petrunin, A. Pure Metric Geometry, 1st ed.; Springer Briefs in Mathematics; Springer: Cham, Switzerland, 2023. [Google Scholar]
- Buneman, P. The recovery of trees from measures of dissimilarity. In Mathematics in the Archaeological and Historical Sciences; Hodson, F.R., Kendall, D.G., Eds.; Edinburgh University Press: Edinburgh, UK, 1971; pp. 387–395. [Google Scholar]
- Huber, K.T.; Koolen, J.; Moulton, V. On the structure of the tight-span of a totally split-decomposable metric. Eur. J. Comb. 2006, 27, 461–479. [Google Scholar] [CrossRef] [Scilit]
- Huber, K.T.; Koolen, J.; Moulton, V. The tight-span of an antipodal metric space: Part I-combinatorial properties. Discret. Math. 2005, 303, 65–79. [Google Scholar] [CrossRef] [Scilit]
- Huber, K.T.; Koolen, J.; Moulton, V. The tight-span of an antipodal metric space: Part II-geometrical properties. Discret. Comput. Geom. 2004, 31, 567–586. [Google Scholar] [CrossRef] [Scilit]
- Lang, U. Injective hulls of certain discrete metric spaces and groups. J. Topol. Anal. 2013, 5, 297–331. [Google Scholar] [CrossRef] [Scilit]
- Suter, R. Injective hulls of odd cycles. arXiv 2013, arXiv:1302.1329. [Google Scholar] [CrossRef] [Scilit]
- Lim, S.; Memoli, F.; Wan, Z.; Wang, Q.; Zhou, L. Some results about the Tight Span of spheres. arXiv 2021, arXiv:2112.12646. [Google Scholar] [CrossRef] [Scilit]
- Grünbaum, B. Convex Polytopes, 2nd ed.; Graduate Texts in Mathematics; Springer: New York, NY, USA, 2003; Volume 221. [Google Scholar]
- Bandelt, H.-J.; Chepoi, V. Metric graph theory and geometry: A survey. Contemp. Math. 2008, 453, 49–86. [Google Scholar]
- Huber, K.T.; Koolen, J.; Moulton, V. The polytopal structure of the tight-span of a totally split-decomposable metric. Discret. Math. 2019, 342, 868–878. [Google Scholar] [CrossRef] [Scilit]
- Gómez, M. Vietoris-Rips Complexes of Split-Decomposable Spaces. arXiv 2025, arXiv:2403.15655. [Google Scholar]
- Pavón, M. Geometry and Structure of Metric Injective Hulls. Doctoral Thesis, ETH-Zürich, Zürich, Switzerland, 2016. Nr. 23120. [Google Scholar] [CrossRef] [Scilit]
- Herrmann, S.; Joswig, M. Splitting polytopes. Münster J. Math. 2008, 1, 109–141. [Google Scholar]
- Dress, A.; Huber, K.T.; Moulton, V. An explicit computation of the injective hull of certain finite metric spaces in terms of their associated Buneman complex. Adv. Math. 2002, 168, 1–28. [Google Scholar] [CrossRef] [Scilit]
- Dress, A.; Huber, K.T.; Moulton, V. A comparison between two distinct continuous models in projective cluster theory: The median and the tight-span construction. Ann. Comb. 1998, 2, 299–311. [Google Scholar] [CrossRef] [Scilit]
- Mankiewicz, P. On Extension of Isometries in Normed Linear Spaces. Bull. Acad. Polon. Sci. Sér. Sci. Math. Astronom. Phys. 1972, 20, 367–371. [Google Scholar]
- Chatterji, I.; Niblo, G. From wall space to CAT(0) cube complexes. Int. J. Algebra Comput. 2005, 15, 875–885. [Google Scholar] [CrossRef] [Scilit]
- Chepoi, V. Graphs of some CAT(0) complexes. Adv. Appl. Math. 2000, 24, 125–179. [Google Scholar] [CrossRef] [Scilit]
- Bridson, M.R.; Haefliger, A. Metric Spaces of Non-Positive Curvature; Grundlehren der Mathematischen Wissenschaften; Springer: Berlin/Heidelberg, Germany, 1999; Volume 319. [Google Scholar]
- Dress, A.; Huber, K.T.; Moulton, V. Some variations on a theme by Buneman. Ann. Comb. 1997, 1, 339–352. [Google Scholar] [CrossRef] [Scilit]
- Graham, R.L.; Knuth, D.E.; Patashnik, O. Concrete Mathematics. A Foundation for Computer Science, 2nd ed.; Addison-Wesley Publishing Company: Reading, MA, USA, 1994. [Google Scholar]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the author. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).