1. Introduction
Short-term dynamic lighting regulation serves as the core support for the safe and low-carbon operation of expressway tunnels. Dramatic natural light differences between tunnel interiors and exteriors, coupled with continuous visibility degradation caused by exhaust fumes and dust, as well as fluctuating real-time traffic flow and vehicle speeds, continuously amplify the drawbacks of conventional static lighting schemes. During low-visibility periods, insufficient road surface illuminance easily triggers rear-end collisions; while constant high luminance under light traffic conditions leads to massive power waste.
Existing tunnel lighting optimization systems suffer from two critical deficiencies:
- −
Single-dimensional environmental perception and underutilization of visual monitoring data. Most current studies only collect two types of traffic parameters, namely traffic volume and vehicle speed, while ignoring the impact of visibility attenuation induced by tunnel dust and exhaust on light transmittance efficiency. Quantitative correlation modeling between visibility and luminance based on visual acquisition is rarely developed. Visual sensors feature lower deployment and maintenance costs and can output multi-dimensional quantitative data including road surface luminance and smoke concentration synchronously; nevertheless, such visually quantified features are barely integrated into lighting-control models [
1,
2].
- −
Lack of multi-parameter coupled modeling and scenario-specific dynamic compensation mechanisms. Most intelligent dimming models only realize basic flow-based light adjustment without differentiating differentiated lighting demands for tunnel entrance sections, transition sections, middle sections and exit sections. The semi-enclosed middle tunnel segment has the lowest visibility and the highest safety risks, yet existing algorithms fail to establish dynamic compensation strategies for luminance loss targeting this zone, making them incapable of adapting to diverse spatiotemporal working conditions including sunny, cloudy, rainy and foggy days [
3,
4].
Recent studies have increasingly introduced data-driven and intelligent methods into tunnel lighting and low-light transportation environments. Zhao et al. developed an intelligent tunnel-lighting control method based on a long short-term memory (LSTM) neural network, using traffic flow, vehicle speed, and external luminance as model inputs, and evaluated its lighting and energy-saving performance through three-dimensional DIALux simulation [
5]. Niu et al. investigated the effects of multiple operating parameters on tunnel lighting, quantified the relationship between visibility and road surface luminance, and incorporated this relationship into a multi-parameter intelligent lighting-control framework [
6]. In the broader field of intelligent transportation systems, Wang et al. proposed a deep-learning-based semantic-segmentation framework for low-light autonomous-driving road scenes, highlighting the importance of intelligent perception under degraded illumination conditions [
7]. Nevertheless, the explicit integration of visibility-dependent luminance attenuation with real-time intelligent tunnel-lighting control remains insufficiently investigated. To address the above issues, this paper integrates tunnel visual quantification technology with fuzzy neural networks to construct a dynamic optimization model for tunnel lighting oriented toward heterogeneous environments. Its three main innovative contributions are summarized as follows:
- −
A multi-parameter field characterization method is established for tunnel lighting environments. Time-series data on traffic flow, vehicle speed, visibility, and pavement luminance are jointly analyzed; a fitting formula for visibility-related luminance loss is established to achieve precise luminance compensation under low-visibility conditions.
- −
A two-layer dynamic luminance optimization model balancing energy-saving baselines and safety compensation is constructed. First, an energy-saving baseline luminance calculation model based on traffic flow and vehicle speed is built in accordance with design specifications; subsequently, visibility attenuation coefficients are introduced to implement safety-oriented luminance compensation, resolving the defect of fixed parameters in traditional schemes that cannot adapt to dynamic environments [
8].
- −
A fuzzy radial basis function (FRBF) intelligent regulation model is developed. The model adopts a five-layer architecture to describe the nonlinear mapping from visibility, traffic flow, and vehicle speed to the required lighting-control signal. Eighty typical lighting scenarios are mapped to 80 fuzzy control rules, enabling real-time lighting regulation under varying tunnel operating conditions [
9,
10].
The remainder of this paper is organized as follows.
Section 2 presents the field measurement scheme and analyzes the spatiotemporal characteristics of tunnel visibility and pavement luminance.
Section 3 develops the dynamic luminance optimization model and the FRBF-based intelligent control method.
Section 4 reports the simulation and validation results.
Section 5 concludes the paper.
2. Materials and Data Acquisition
Based on the main factors affecting tunnel lighting identified in previous studies, visibility, traffic flow, vehicle speed, and pavement luminance were selected for field measurement and analysis. This section introduces the test tunnel and measurement scheme, identifies the target lighting-control section, and analyzes the relationship between visibility and pavement luminance to provide a basis for the subsequent dynamic compensation model.
2.1. Overview of Test Tunnel and Site Measurement Scheme
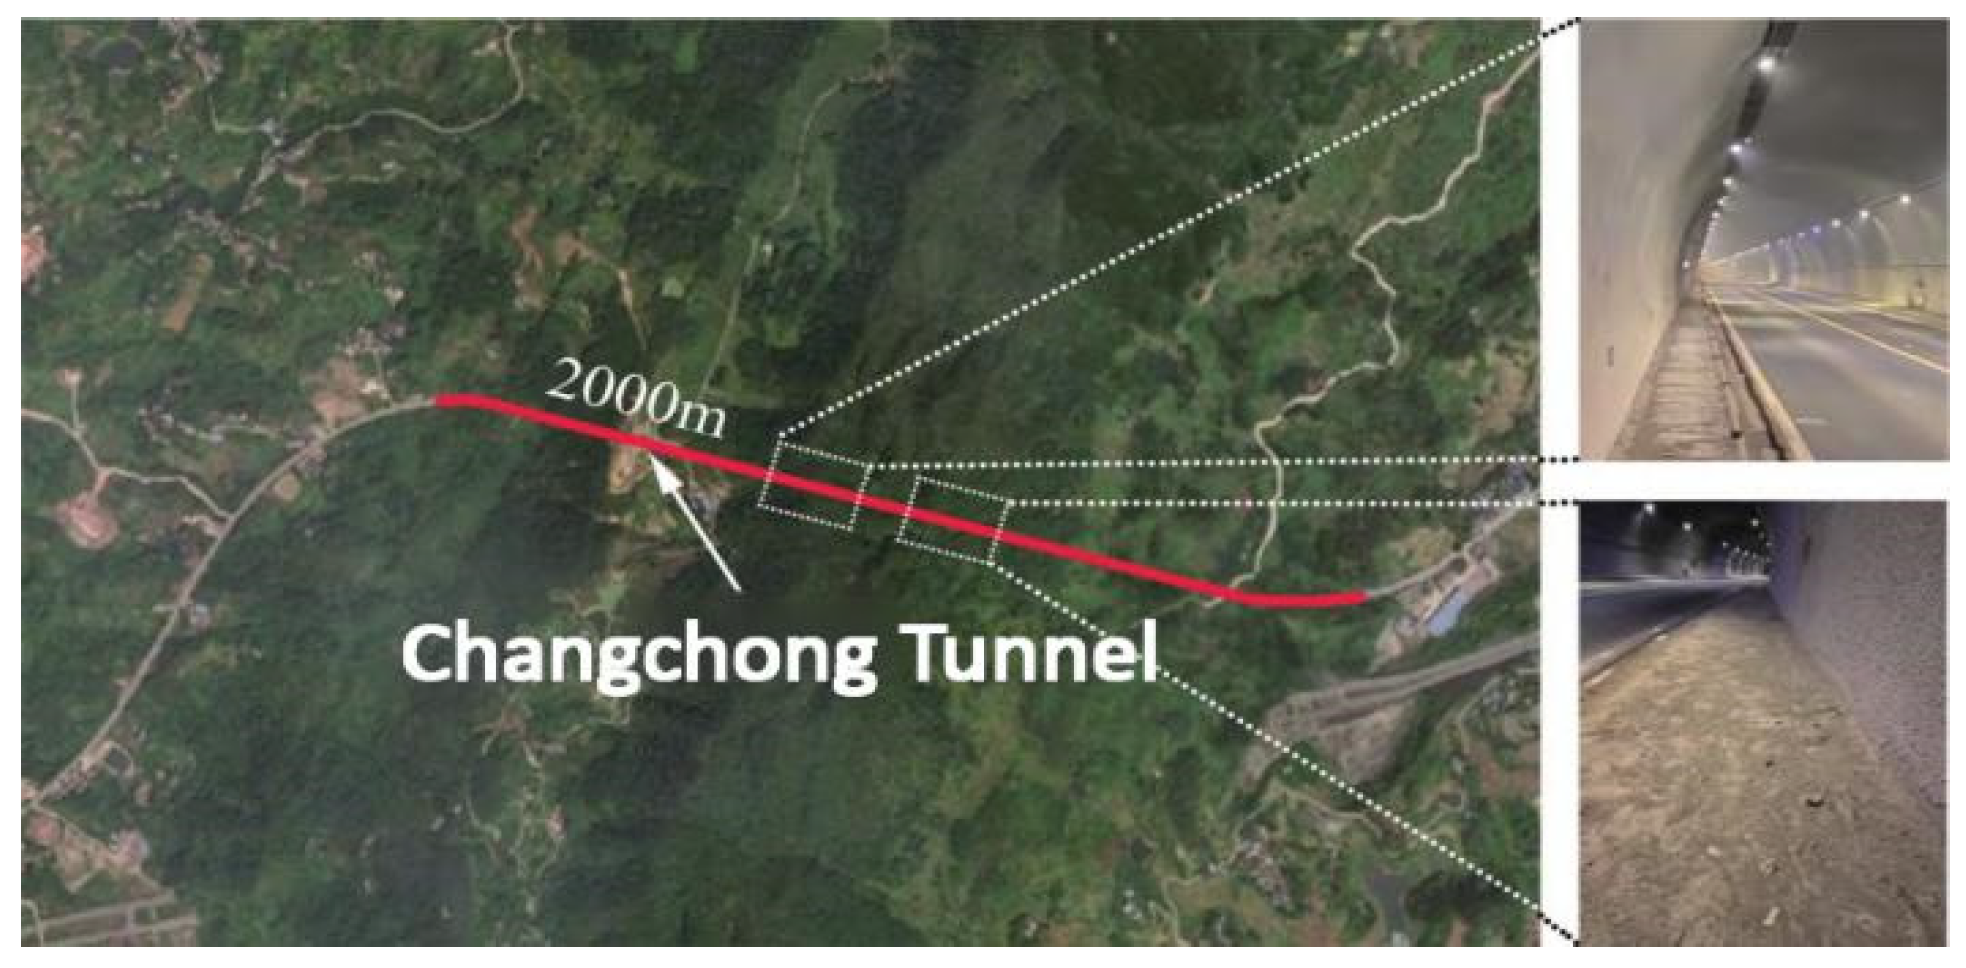
To minimize external interference and highlight the impact of visibility on tunnel lighting, this study selected Changchong Tunnel in Wanzhou District, Chongqing (
Figure 1) as the research site. The tunnel’s daily heavy traffic of sand and gravel trucks, combined with its considerable length, prevents timely removal of pollutants from both the sand mixture and vehicle exhaust. Furthermore, frequent highway fog in Chongqing significantly reduces visibility within the tunnel environment [
11].
Measurement sections were arranged according to the lighting-zone layout. A total of eight measurement sections were defined, and eight measurement points were evenly distributed within each section, resulting in 64 measurement points in total. Field measurements were conducted on 1, 5, 6, 10, 11, and 25 June 2023. The sampling period was selected to maintain a relatively consistent seasonal background while capturing variations in weather and traffic conditions. The six full-day measurement campaigns covered sunny, cloudy, and rainy conditions as well as daytime and nighttime operating periods. The measured data were grouped according to weather condition and time period, and hourly averages were calculated to reduce the influence of short-term fluctuations and measurement errors. Therefore, this sampling design provides a relatively consistent background for examining the effects of weather and traffic conditions on tunnel visibility and pavement luminance [
12].
2.2. Determination of Lighting Control Section
Field measurement data not only covers extensive areas but is also distributed across various lighting zones within the tunnel. Each data point has varying influence levels and potential correlations, posing challenges for tunnel lighting optimization research. This necessitates clearly identifying target optimization zones and their corresponding parameters. By analyzing visibility distribution characteristics in each lighting zone, we can pinpoint the critical areas requiring optimization and regulation under different illumination conditions.
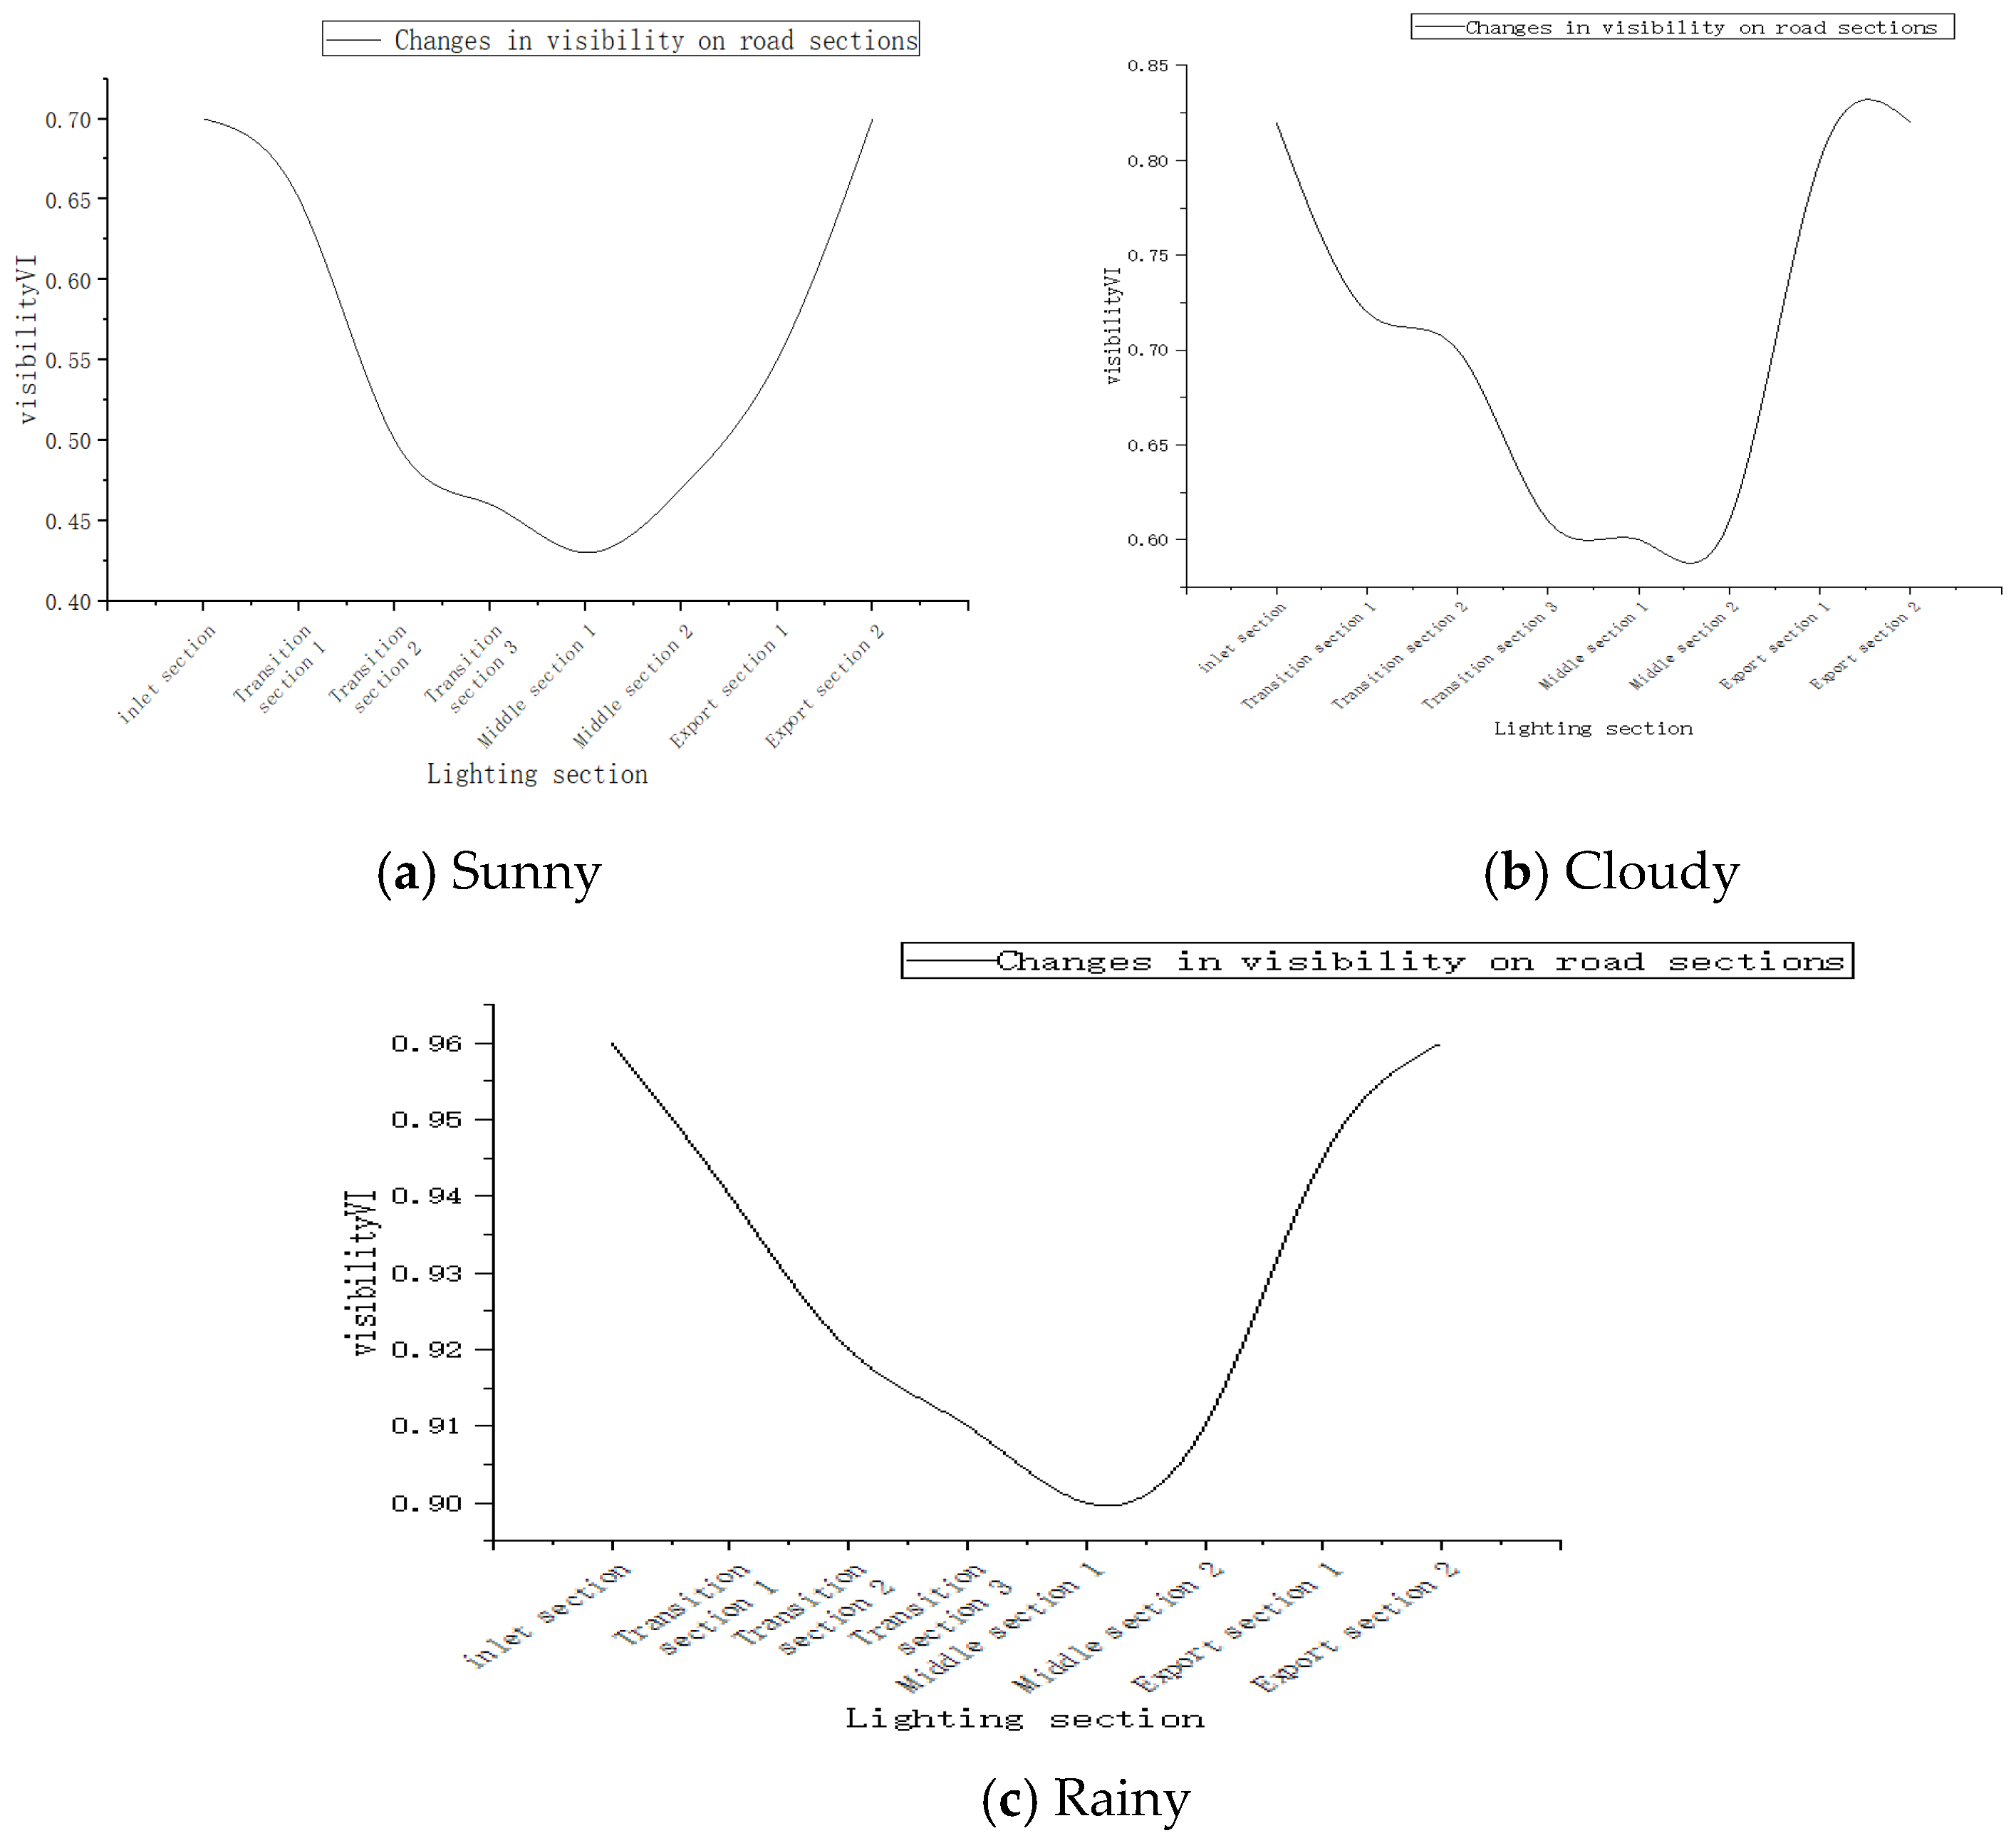
As shown in
Figure 2, visibility within highway tunnels typically first decreases and then recovers along the driving direction, peaking at the entrance and reaching its lowest level in the middle section. The visibility at tunnel entrances/exits is on average 24(%) higher than inside the tunnel, with significant fluctuations, while visibility inside the tunnel shows minimal variation. This occurs because tunnel entrances/exits are adjacent to external environments, where natural vehicle-generated wind carries dust out of the tunnels. In contrast, the middle section forms a semi-enclosed structure that prevents timely exhaust of gaseous pollutants, resulting in poor visual conditions and increased traffic safety risks. Studies indicate that when tunnel lighting brightness is low (L < 30 cd/m
2), enhancing illumination can significantly improve visibility [
13]. Since conventional lighting in the middle section remains below standard levels compared to other areas, boosting its brightness substantially enhances visibility, thereby ensuring driving safety. This study identifies the middle section of highway tunnels as the primary target for brightness optimization. By regulating lighting intensity in this area, we aim to improve visibility and ensure safe passage through the tunnel.
2.3. Tunnel Interior Visibility Data Analysis
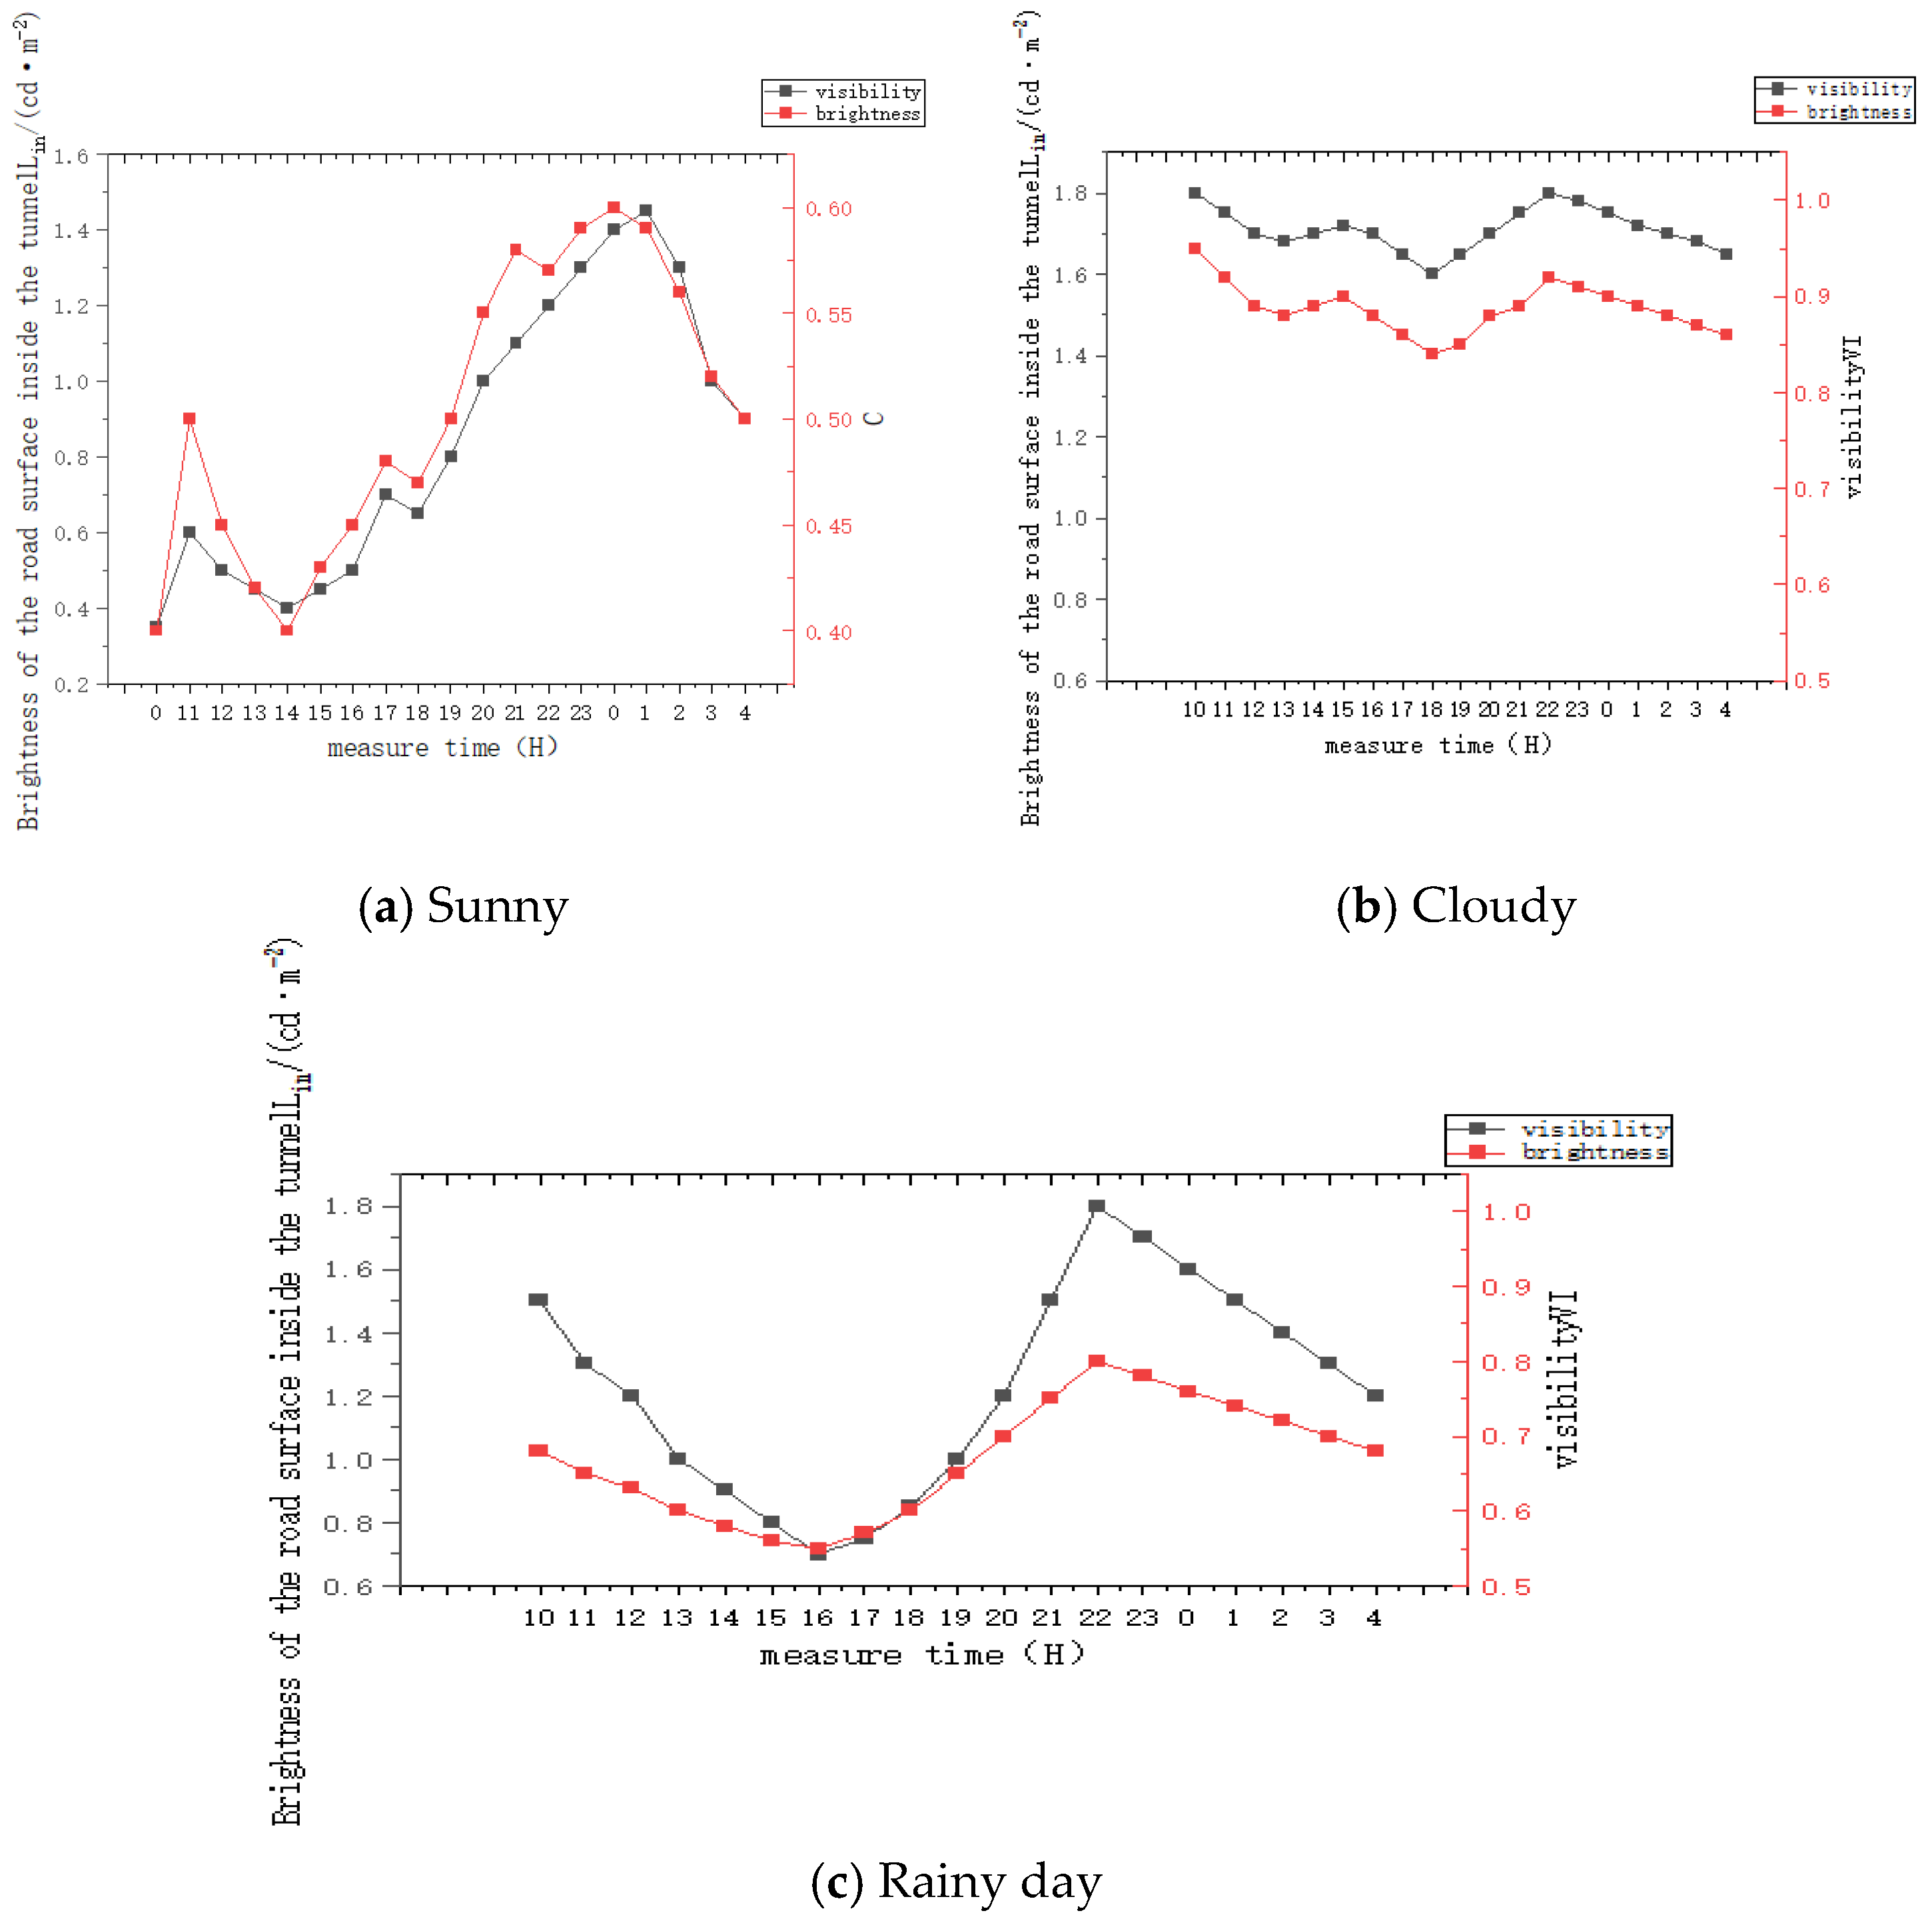
Numerous scholars have conducted extensive research on the relationships between traffic flow, vehicle speed, and lighting brightness. Given the substantial body of existing research, this paper will not repeat previous findings but instead focus on analyzing the spatiotemporal patterns of tunnel pavement brightness and visibility. Through time–weather condition-based classification analysis of tunnel pavement brightness and visibility,
Figure 3 visually presents the dynamic changes in tunnel visibility and pavement brightness using line charts.
As shown in
Figure 3, the road surface luminance in tunnels often fails to meet the design standard on sunny and cloudy days. Tunnel visibility is generally positively correlated with road surface luminance. This relationship can be attributed to the scattering and absorption of light by suspended particles and turbid gases, which reduce light-transmission efficiency and consequently decrease the luminous energy reaching the pavement. Furthermore, nighttime tunnel visibility is significantly higher than daytime visibility, while rainy conditions generally show better visibility than sunny or cloudy conditions. This is mainly because reduced nighttime traffic decreases vehicle exhaust and dust emissions, while wet pavement under rainy conditions suppresses dust dispersion [
14].
As shown in
Figure 3, under low-visibility conditions, if the traditional lighting design scheme specified in the “Highway Tunnel Lighting Design Code” (JTGTD70/2-01-2014, hereinafter referred to as the “Lighting Code”) is still adopted, the tunnel is prone to form a driving environment with insufficient visibility and visual brightness, which poses safety risks. Therefore, it is imperative to develop a method for dynamically optimizing lighting brightness [
15].
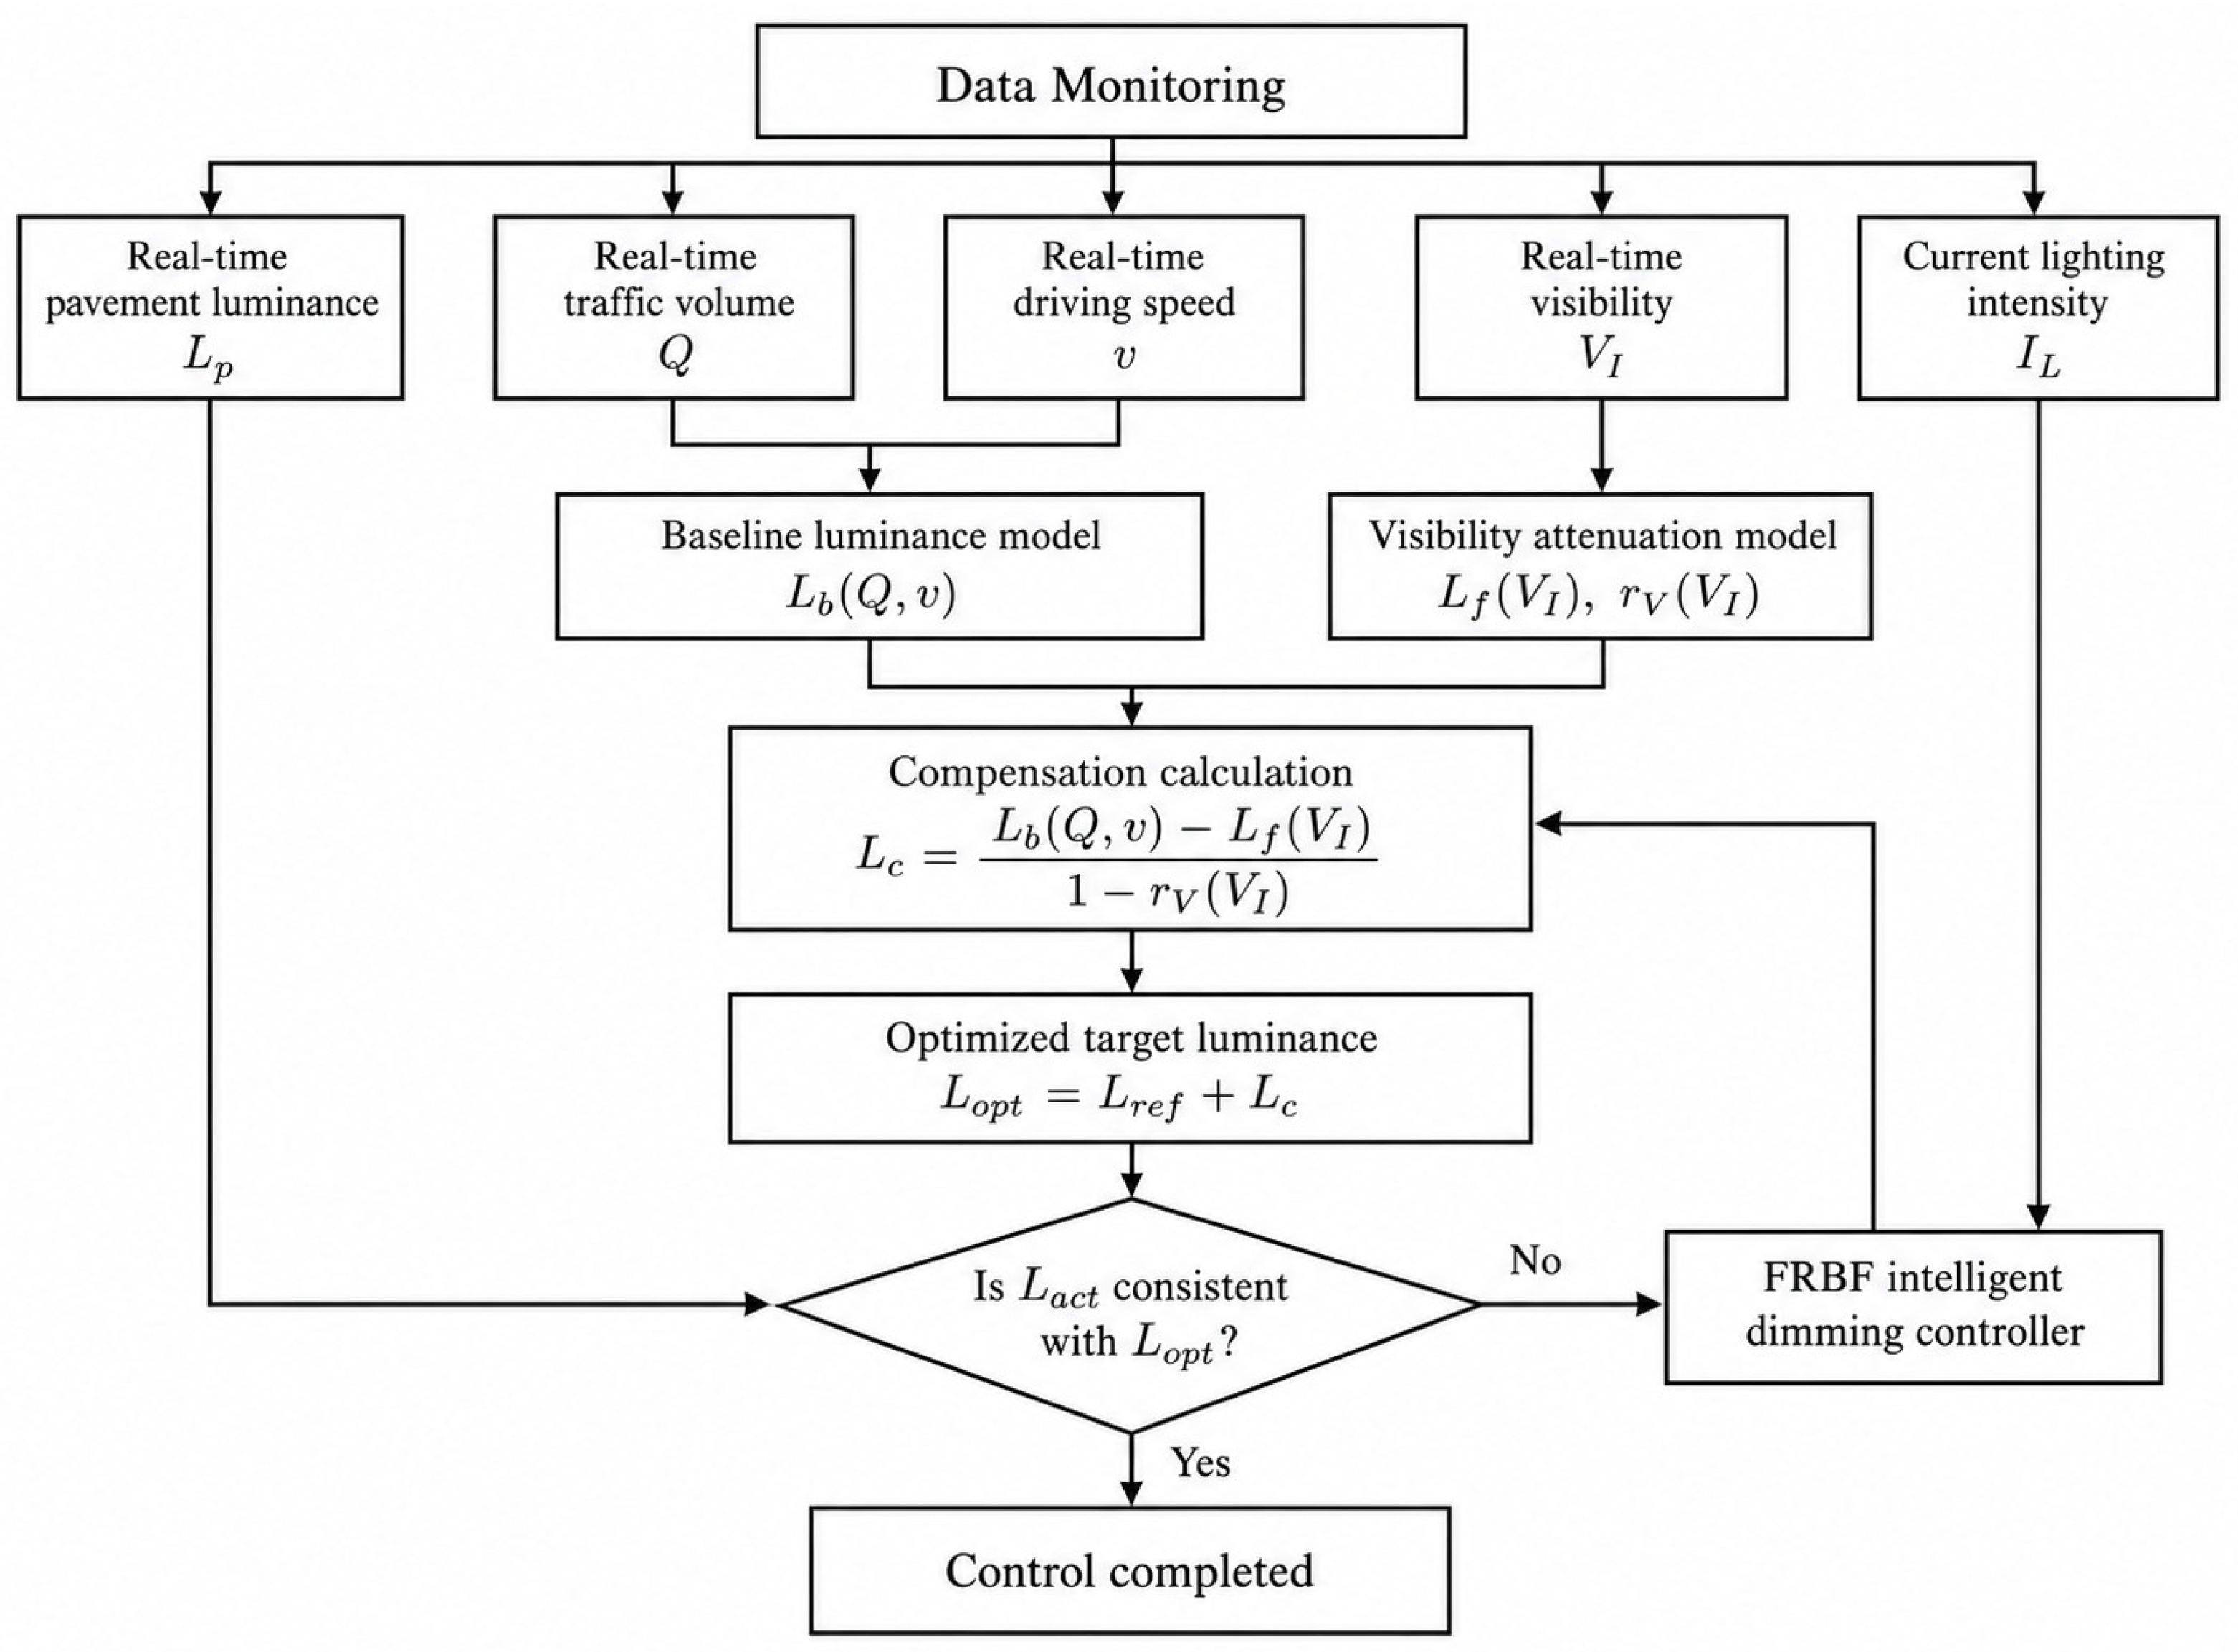
In conclusion, the dynamic lighting-control framework considers visibility index, traffic volume, vehicle speed, real-time pavement luminance, and current lighting intensity. Among them, visibility index, traffic volume, and vehicle speed are used as direct inputs to the FRBF controller, while real-time pavement luminance and current lighting intensity are used for system-state monitoring and feedback evaluation.
3. Methodology
The proposed method combines a traffic-demand-based baseline luminance model, a visibility-dependent attenuation model, and an FRBF neural-network controller. Traffic volume and vehicle speed first determine the baseline pavement luminance required by the current traffic state. The visibility measurements then provide the fitted pavement luminance and the corresponding luminance-loss ratio. Following the compensation relation derived below, the difference between the baseline and fitted luminance is converted into a compensation term, which is added to the reference luminance to obtain the optimized target. The FRBF network subsequently approximates this nonlinear mapping for real-time control. The overall intelligent lighting-control framework is illustrated in
Figure 4.
Let
denote the two-way traffic volume (veh/h),
the mean vehicle speed (km/h),
the dimensionless visibility index,
the traffic-demand-based baseline pavement luminance (cd/m
2),
the pavement luminance fitted from the visibility measurements (cd/m
2),
the reference pavement luminance,
the visibility-induced luminance-loss ratio,
the compensation term, and
the optimized target pavement luminance (cd/m
2). The overall optimization model is expressed as
In the formula, and determine the basic lighting demand, whereas characterizes environmental attenuation. At the reference visibility state, and ; therefore, Equation (1) reduces to . This limiting case preserves the traffic-demand baseline and provides a direct consistency check for the compensation model.
3.1. Traffic-Demand-Based Baseline Luminance Model
The conventional tunnel-lighting design procedure determines pavement luminance from prescribed traffic-flow and design-speed conditions. After construction, however, fixed lighting settings cannot respond effectively to short-term variations in actual traffic demand. To obtain a dynamically adjustable baseline, the standard luminance values specified in Table 6.1.1 of the Chinese highway tunnel lighting design standard [
16] were fitted as functions of vehicle speed for three traffic-volume intervals.
For two-way traffic, the operating conditions are classified as high flow (Q > 650 veh/h), medium flow (180 < Q ≤ 650 veh/h), and low flow (Q ≤ 180 veh/h). The fitted baseline luminance is
where
is expressed in cd/m
2 and v in km/h. The model is applied within the speed range represented by the design-code data used for fitting. The three branches provide a traffic-responsive baseline: lower traffic demand results in a lower target luminance, whereas higher traffic demand and speed require a higher pavement luminance. Because this model does not explicitly represent the effect of reduced tunnel visibility, a visibility-dependent attenuation model is introduced below.
3.2. Visibility-Dependent Luminance Attenuation Model
Field measurements showed that pavement luminance decreased as tunnel visibility deteriorated even when the lighting setting remained unchanged. This relationship is treated as an empirical environmental attenuation effect. The visibility index therefore serves as an observable variable that reflects the combined influence of suspended dust, exhaust emissions, and turbid air on the effective pavement luminance [
17].
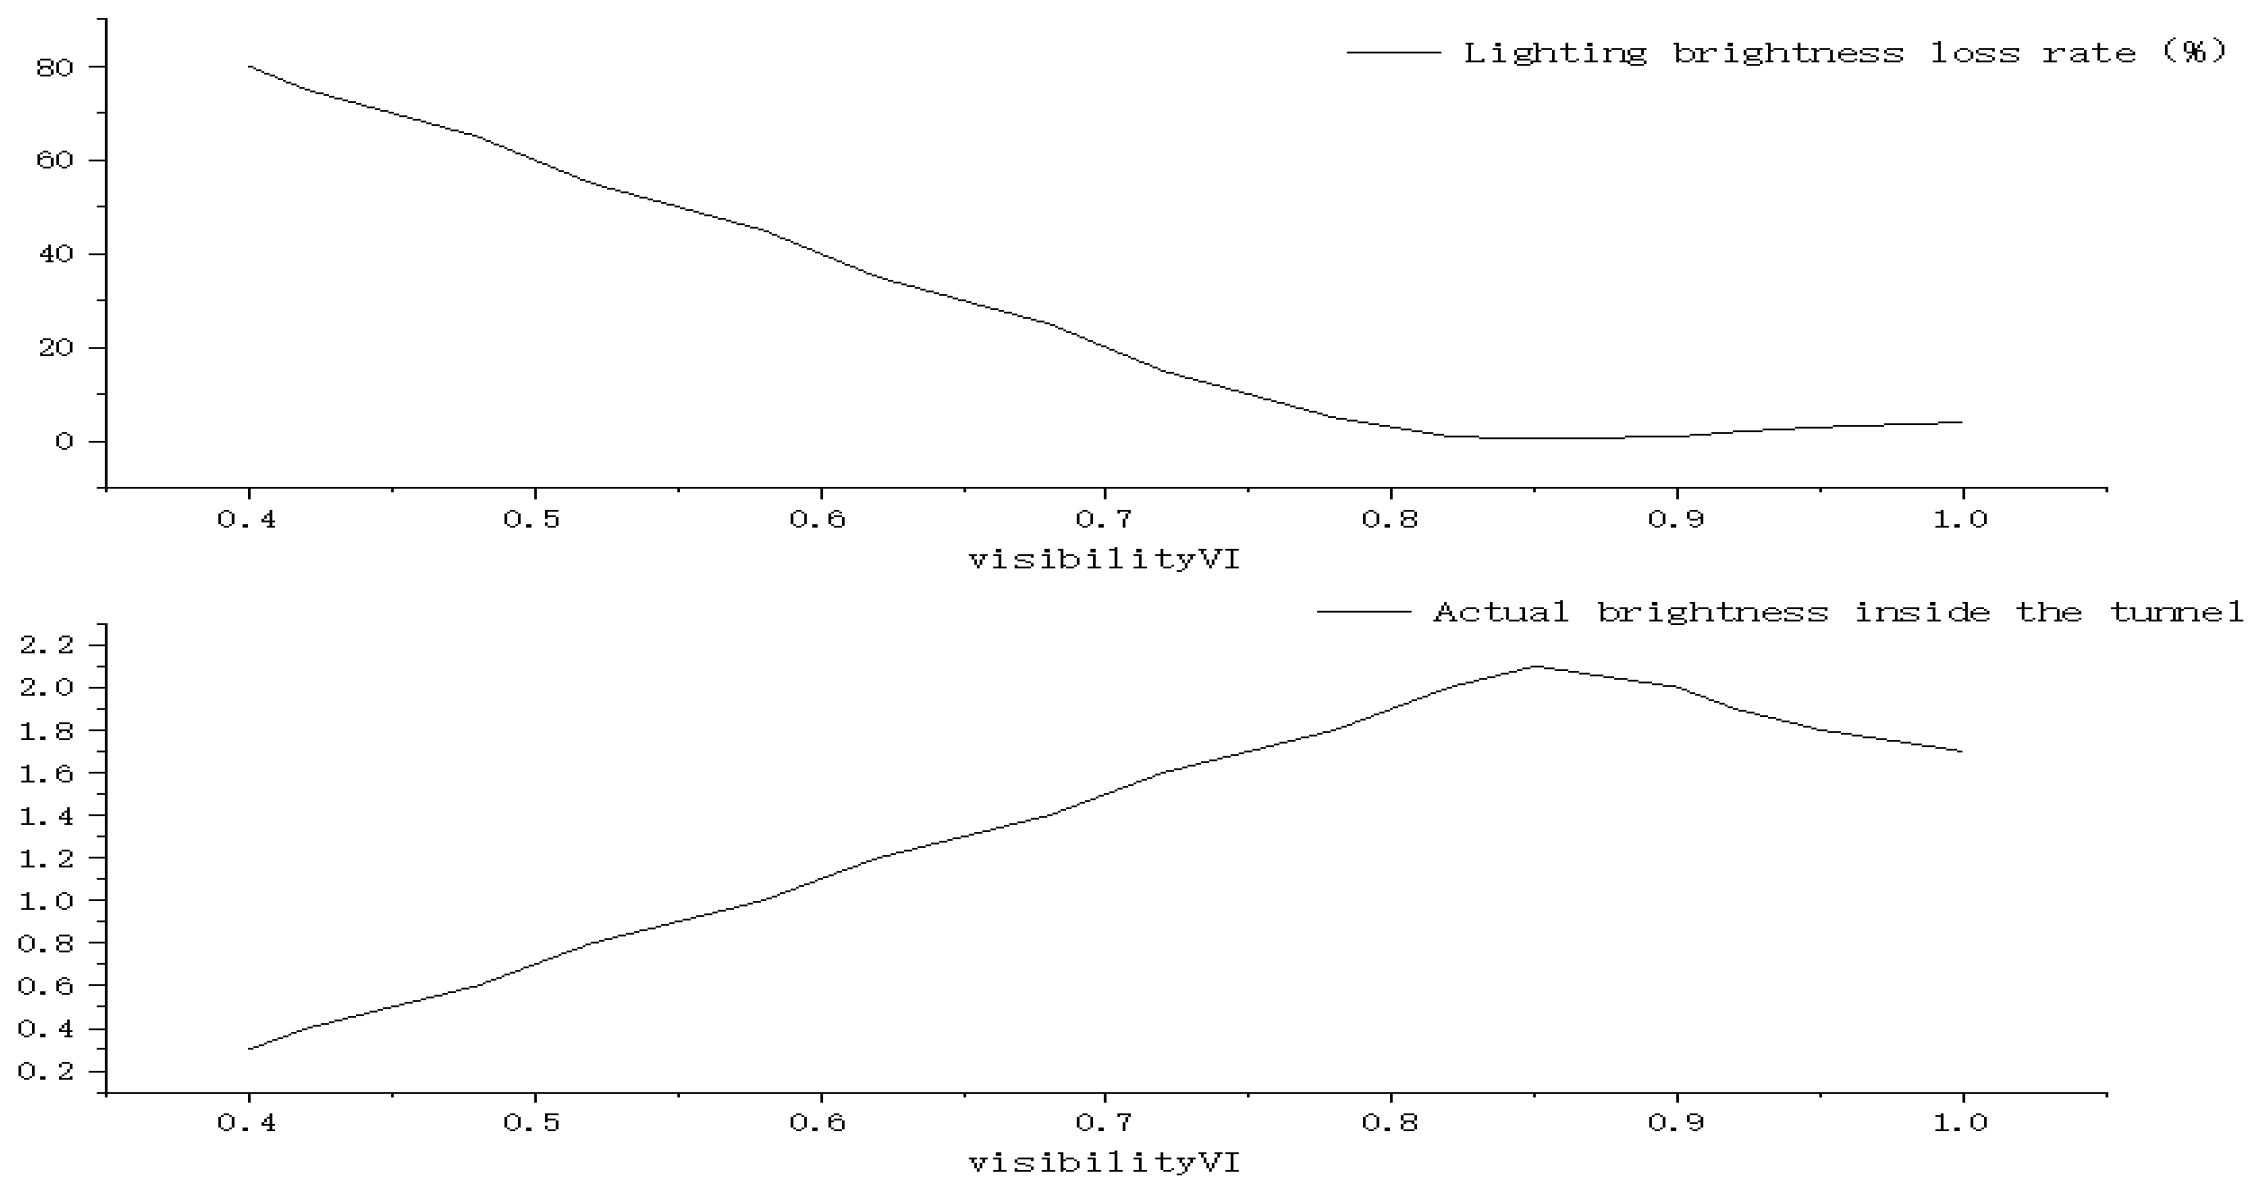
Based on the paired visibility–luminance measurements obtained in the middle section of the test tunnel, the fitted relationship is
where
is the dimensionless visibility index and L_f is the fitted pavement luminance in cd/m
2. The fitted relationship yielded R
2 = 0.958, and the fitting error was maintained within 5%.
Figure 5 illustrates the measured visibility–luminance relationship and the corresponding luminance-loss trend.
At the reference visibility state V_I = 1, the fitted pavement luminance is
The visibility-induced luminance-loss ratio is defined as
where
= 0 corresponds to the reference visibility state, while a larger r_V represents a greater reduction in effective pavement luminance. Substitution of Equations (3) and (4) into Equation (5) gives
Equation (6) is an empirical attenuation relationship obtained from the measured tunnel data and is used only within the calibrated visibility interval.
3.3. Dynamic Luminance Compensation
Let
denote the luminance compensation term. Consistent with the balance among the traffic-demand baseline, the visibility-dependent fitted luminance, and the visibility-induced loss ratio, the compensation relation is written as
Rearranging Equation (7) gives
Substituting Equations (3) and (6) into Equation (8) yields the explicit compensation term
The optimized target luminance is obtained by adding the compensation term to the reference luminance:
The resulting two-step formulation first calculates the visibility-related compensation term and then adds it to the reference luminance. Because and , it yields at the reference visibility state. In implementation, the model is evaluated only over the domain specified above, and the final target is constrained by the allowable dimming range and the luminance limits of the installed lighting system.
3.4. FRBF-Based Real-Time Intelligent Control Model
Direct real-time evaluation of the piecewise baseline model and the visibility-compensation equations increases computational complexity in continuous lighting control. An FRBF neural network is therefore used to approximate the nonlinear relationship between the three operating variables and the optimized target luminance [
18,
19,
20,
21]. The network output can be represented as
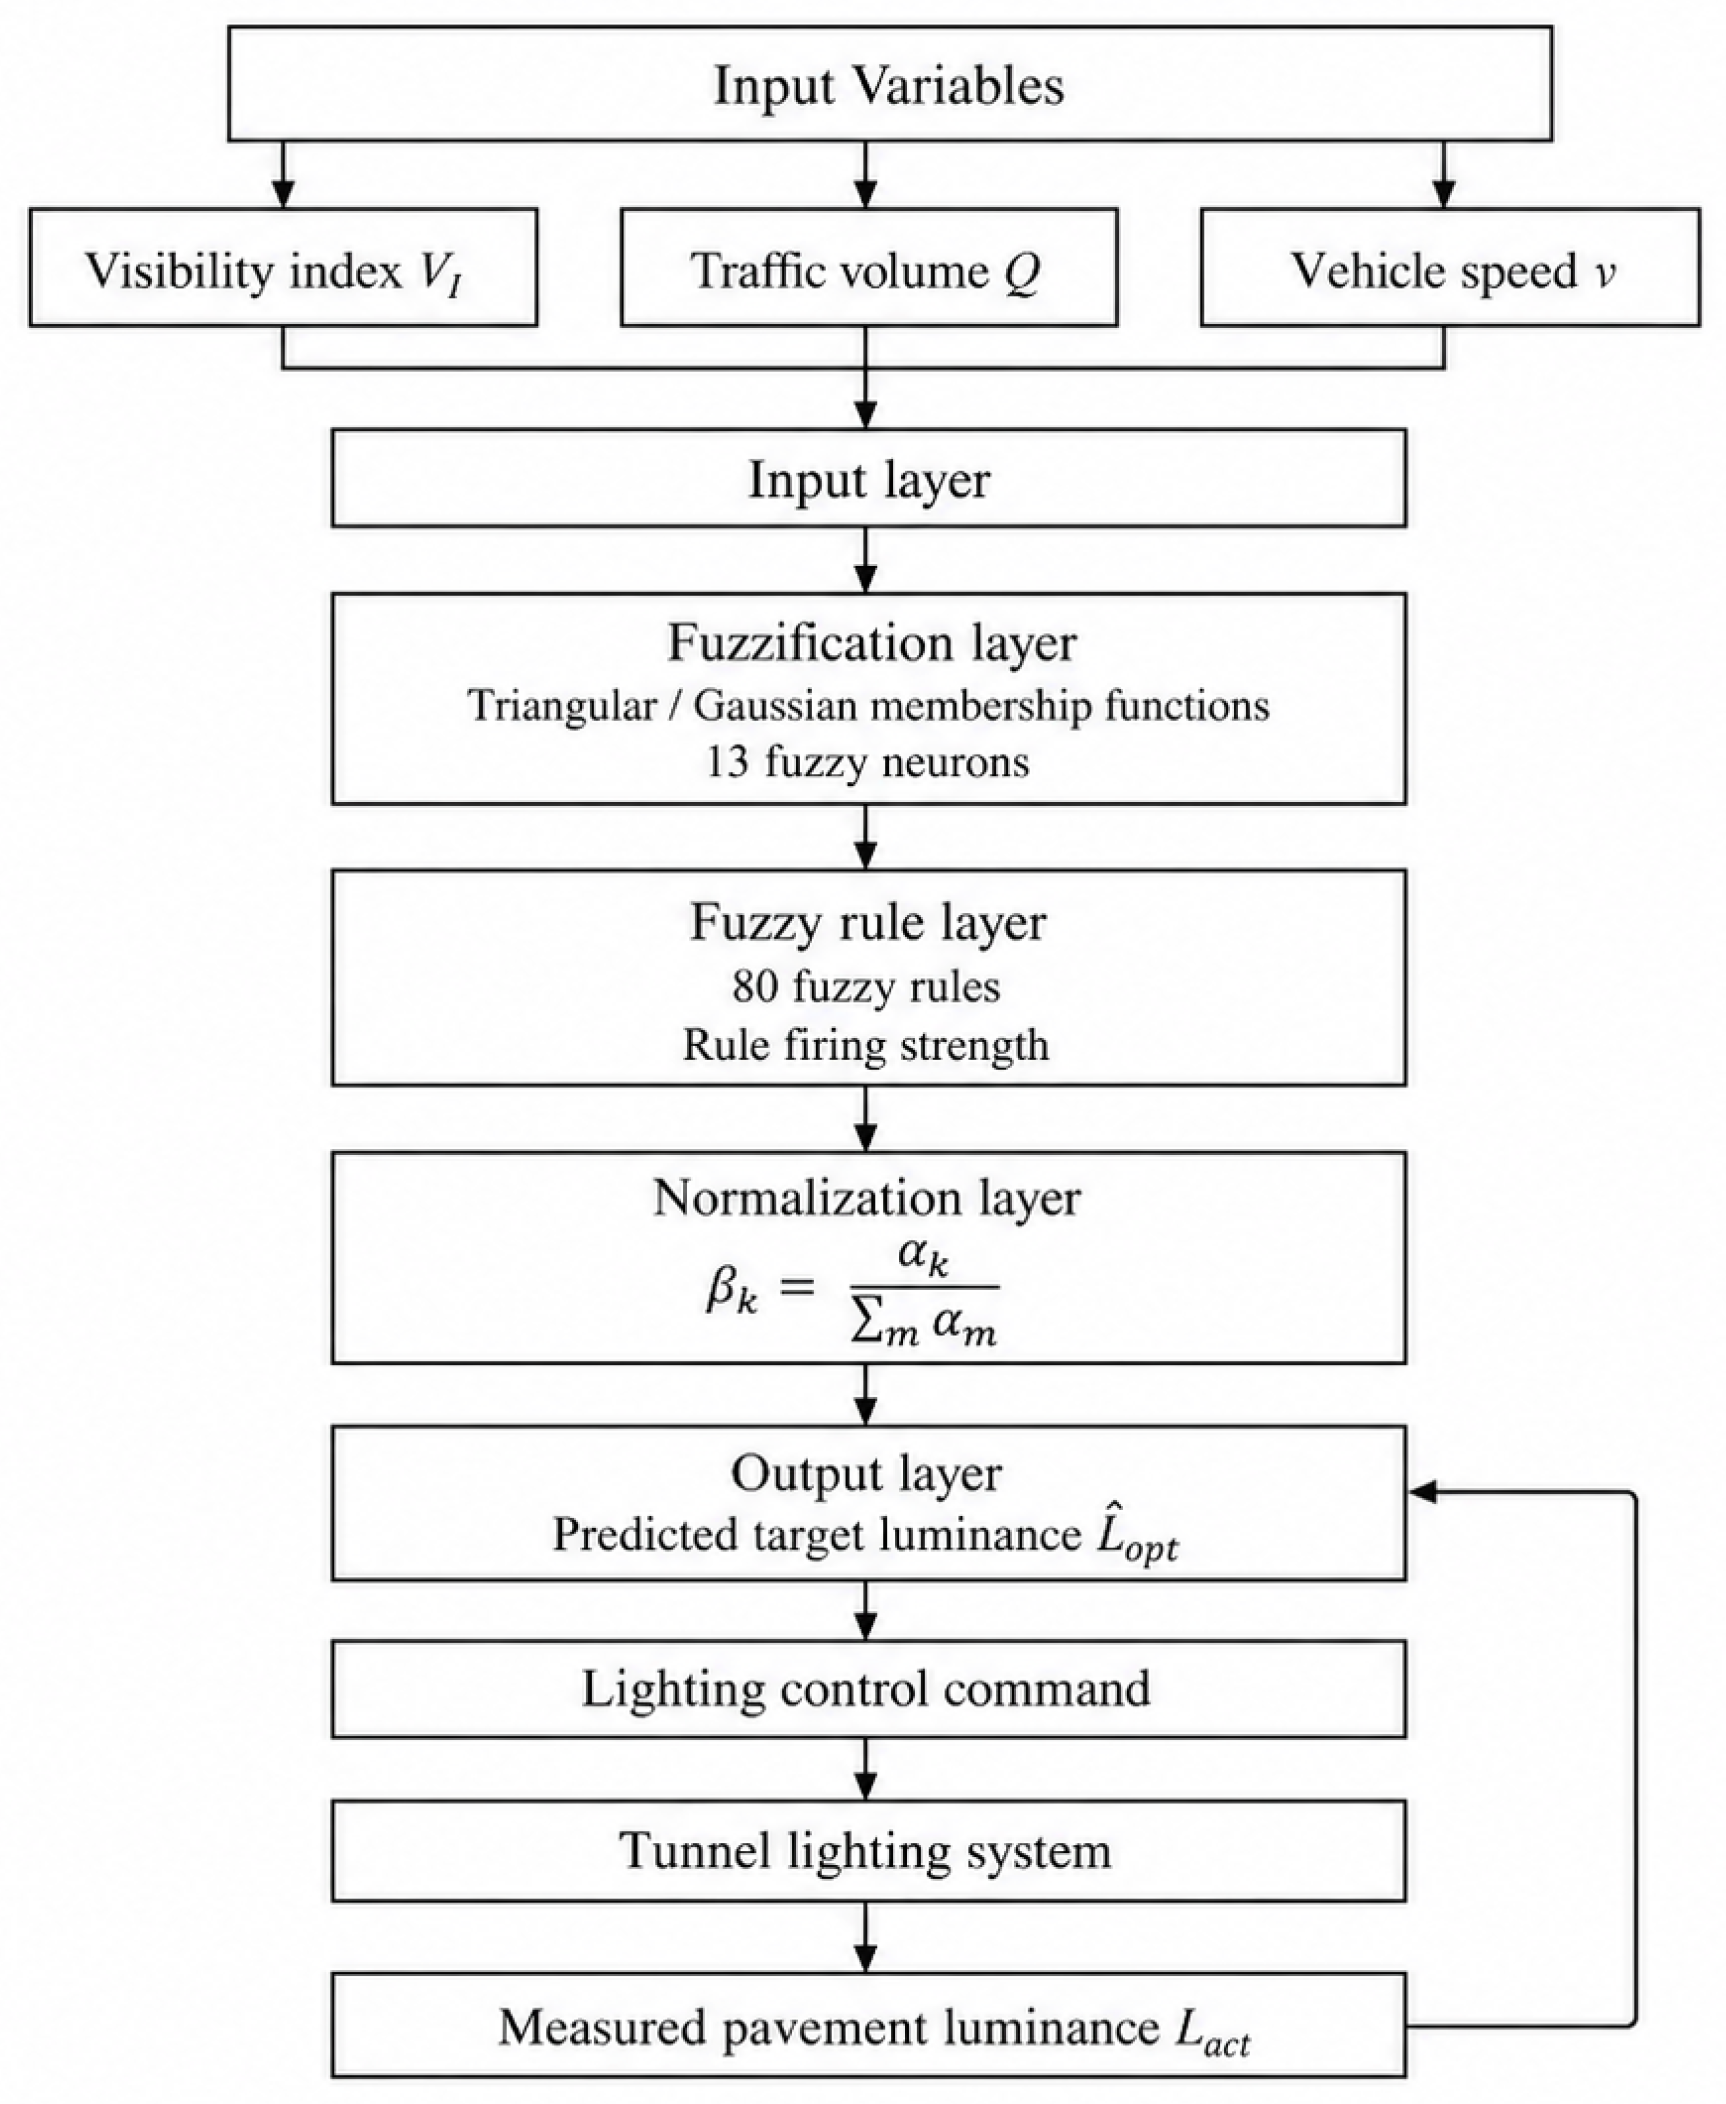
where Θ denotes the trainable parameters of the FRBF model. The three network inputs are visibility index, traffic volume, and vehicle speed, and the single output is the optimized target luminance. The network consists of five layers: input, fuzzification, fuzzy-rule, normalization, and output layers. The schematic diagram of the FRBF-Based Real-Time Intelligent Control Model is shown in
Figure 6.
Layer 1: Input Layer
The three variables are normalized before being passed to the fuzzification layer, and the same normalization rule is used during training, testing, and online control.
Layer 2: Fuzzification Layer
The fuzzification layer converts each normalized input into membership degrees. The network contains 13 fuzzification nodes. The membership functions are distributed across the three input dimensions to generate 80 rule combinations. Triangular and Gaussian membership functions are used to represent the linguistic states of the input variables.
A triangular membership function is expressed as
and a Gaussian membership function is expressed as
where
denotes the membership degree of the j-th fuzzy set for the i-th input;
,
, and
define the triangular membership function; and c_ij and σ_ij are the center and width of the Gaussian membership function, respectively.
Layer 3: Fuzzy-Rule Layer
Each neuron in the fuzzy-rule layer represents one control rule. For the k-th rule, the firing strength is calculated from the membership degrees of the three antecedent variables as
where j_i(k) denotes the membership-function index selected by rule k for input x_i. The geometric mean limits excessive attenuation of the rule activation when one antecedent membership degree is small.
Layer 4: Normalization Layer
The firing strengths of the 80 rules are normalized according to
so that
= 1.
Layer 5: Output Layer
For a zero-order T–S fuzzy consequent, each rule is associated with a consequent parameter w_k. The FRBF output is
The network therefore converts the current visibility, traffic volume, and vehicle speed into a real-time estimate of the optimized target luminance.
4. Experiments
The experiments are organized to evaluate four aspects of the proposed framework: reproducibility of the dataset and measurement procedure, predictive accuracy of the FRBF model, contribution of the visibility-compensation and fuzzy-control components, and the performance of the resulting dimming strategy under time-varying tunnel conditions. Field measurements, model training, SUMO-based time-series validation, and DIALux lighting simulation are reported separately.
4.1. Dataset Construction and Measurement Configuration
- (1)
Dataset Composition
The lighting-control database contains 124 measured operating samples assembled from the Changchong Tunnel measurements and additional highway-tunnel measurements. Each sample contains
, and its target output
is calculated using the optimization model in
Section 3. Of the 124 samples, 99 samples are used for training and 25 samples are reserved as an independent test set. The identity, location, acquisition period, and sample contribution of each tunnel are listed in
Table 1.
- (2)
Measurement Instruments and Data Quality Control
Visibility, traffic volume, vehicle speed, and pavement luminance are acquired at synchronized or temporally matched measurement intervals. To ensure reproducibility, the instrument model, measurement range, accuracy, sampling interval, calibration procedure, and data-quality treatment are documented in
Table 2. Invalid records and outliers are processed according to the stated criterion before dataset splitting.
- (3)
Typical Lighting Scenarios and FRBF Rule Configuration
The original control framework uses 80 typical lighting scenarios and an 80-rule FRBF inference layer. To make the rule base traceable, each scenario is classified according to the operating-state variables used by the controller.
Table 3 records the fuzzy partition assigned to each input and the number of linguistic states; The corresponding fuzzy partitions and rule configuration are summarized in
Table 3.
The FRBF controller directly uses visibility index VI, traffic volume Q, and vehicle speed v as its three input variables. Real-time pavement luminance Lp and the current lighting state are used for system monitoring and feedback evaluation rather than as direct inputs to the FRBF inference layer.
4.2. Model Training and Hyperparameter Settings
The training samples are used to optimize the membership-function parameters and rule consequent parameters of the FRBF network. The maximum number of iterations is 1000 and the target training-error threshold is 0.01. All preprocessing parameters are estimated from the training set and then applied unchanged to the independent test set. The remaining implementation settings are summarized in
Table 4.
4.3. Evaluation Metrics
Prediction performance is evaluated only on the 25-sample independent test set. Let y_n denote the target optimized luminance and ŷ_n the FRBF prediction for test sample n. The coefficient of determination, root mean square error, mean absolute error, and mean absolute percentage error are defined as follows.
All metrics are calculated using the same independent test samples. Training-set metrics may be reported separately but are not used as evidence of generalization performance.
4.4. Experimental Results and Analysis
- (1)
FRBF Prediction Performance
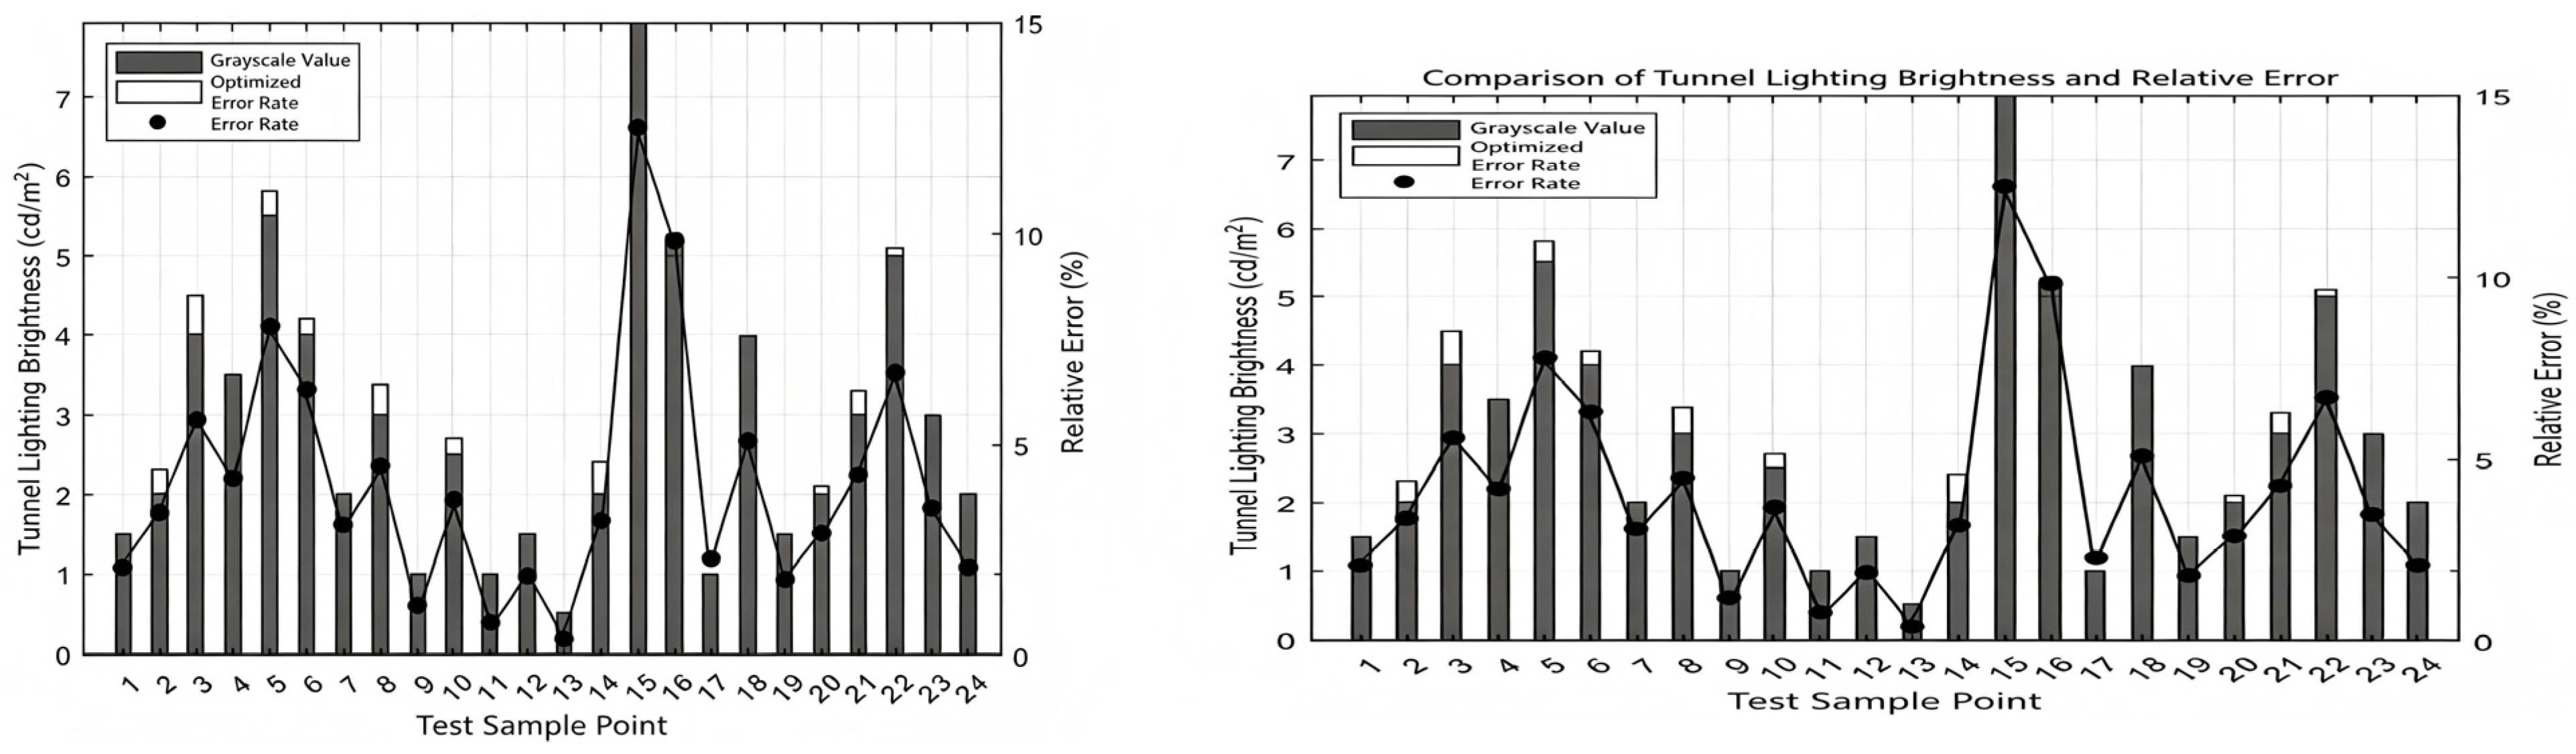
Figure 7 presents the sample-by-sample comparison results for all test samples, including the target luminance, the luminance predicted by the FRBF model, and the corresponding relative error.
The sample-wise comparison in
Figure 7 is used to examine whether the FRBF network can reproduce the optimized luminance obtained from the dynamic optimization model. Quantitative performance is evaluated using the test-set R
2, RMSE, MAE, and MAPE defined in
Section 4.3. All four metrics are calculated from the same 25 test samples; the 99 training samples are not included in these test-performance calculations. The final values obtained after model retraining are reported in
Table 5.
A higher R
2 together with lower RMSE, MAE, and MAPE indicates closer agreement between the FRBF prediction and the optimized target luminance. The final
Figure 7 and
Table 5 should be generated from the same 25-sample test set to ensure consistency between the graphical and numerical results.
- (2)
SUMO-Based Time-Series Control Validation
To evaluate the response of the proposed control method under continuously varying traffic conditions, the field data collected from Changchong Tunnel in March 2024 were organized chronologically. Traffic-flow and vehicle-speed sequences were reproduced in SUMO for a 24 h operating period. The simulation output interval was 30 min, resulting in 48 operating conditions. The corresponding measured visibility data were synchronized with the traffic states and then used together as inputs to the FRBF control model. SUMO was used for the traffic-state sequence rather than for generating visibility or pavement-luminance data. The main SUMO simulation and calibration settings are summarized in
Table 6.
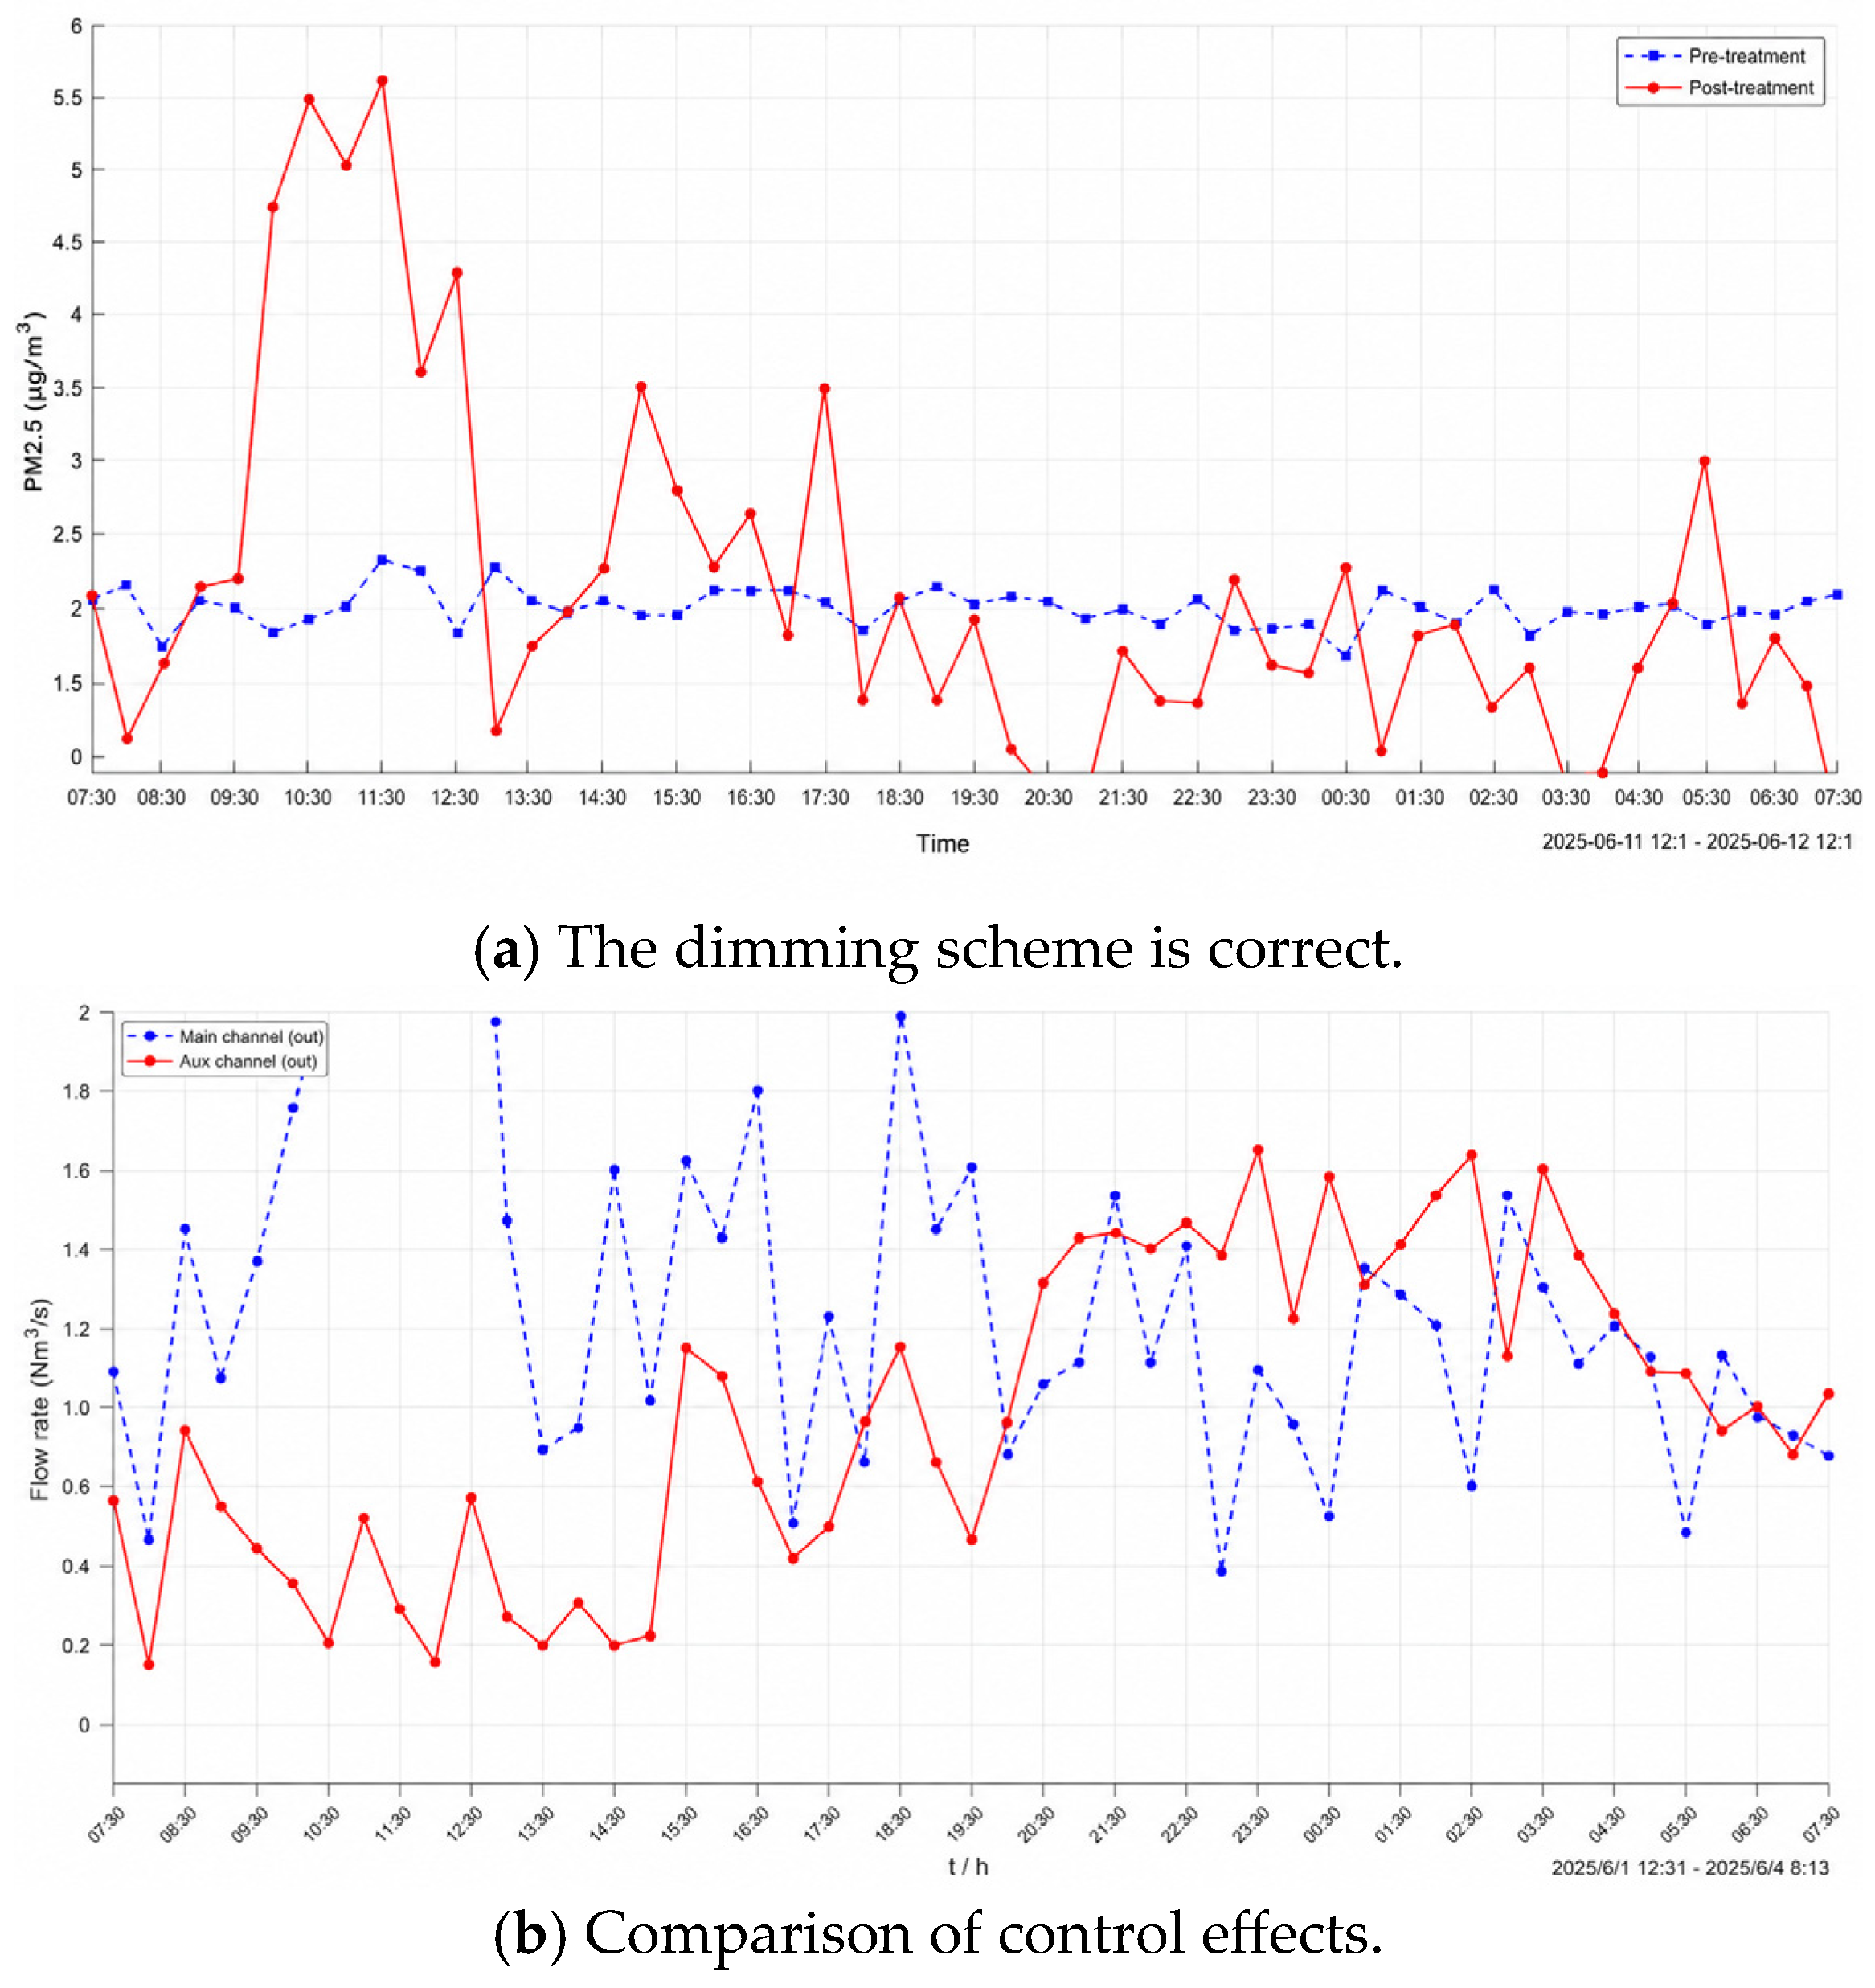
Figure 8 compares the conventional dimming strategy with the proposed control method.
Figure 8a presents the time-series dimming commands, whereas
Figure 8b compares the corresponding control effects. The conventional strategy primarily responds to traffic flow and vehicle speed, while the proposed method further incorporates the visibility-dependent compensation established in
Section 3.
As shown in
Figure 8a, luminaire light-distribution characteristics and operating brightness are important factors affecting tunnel pavement lighting performance [
22]. Conventional control methods primarily adjust luminaire brightness according to traffic flow and vehicle speed, resulting in limited effectiveness under tunnel conditions with relatively small traffic fluctuations. In contrast, the intelligent control method proposed in this study prioritizes real-time road surface brightness optimization. It dynamically adjusts tunnel lighting systems in real time based on changes in visibility, traffic volume, vehicle speed, and road surface brightness conditions.
Figure 8b presents the tunnel roadway brightness test results obtained through intelligent control methods. The standard deviation of roadway brightness under conventional control methods was 0.47 cd/m
2, showing significant deviations from the designed brightness values. In contrast, the method proposed in this study achieved a standard deviation of merely 0.09 cd/m
2. This demonstrates that regardless of variations in lighting conditions, the tunnel roadway brightness remains stable near the design value, with fluctuations consistently controlled within error margins. These findings indicate that the dynamic optimization and intelligent control approach for highway tunnel illumination is both scientifically sound and practically effective [
23].
- (3)
DIALux Lighting Simulation and Control Performance
Because direct dynamic dimming tests in an operating tunnel involve practical and safety constraints, DIALux is used to evaluate the lighting effect of the control commands in a three-dimensional tunnel model. The sidewall and ceiling reflectance coefficients are set to 0.05, and the pavement reflectance coefficient is set to 0.18. The external environmental luminance varies from 0 to 2646.03 cd/m
2. The geometric and luminaire parameters used in the DIALux model are summarized in
Table 7.
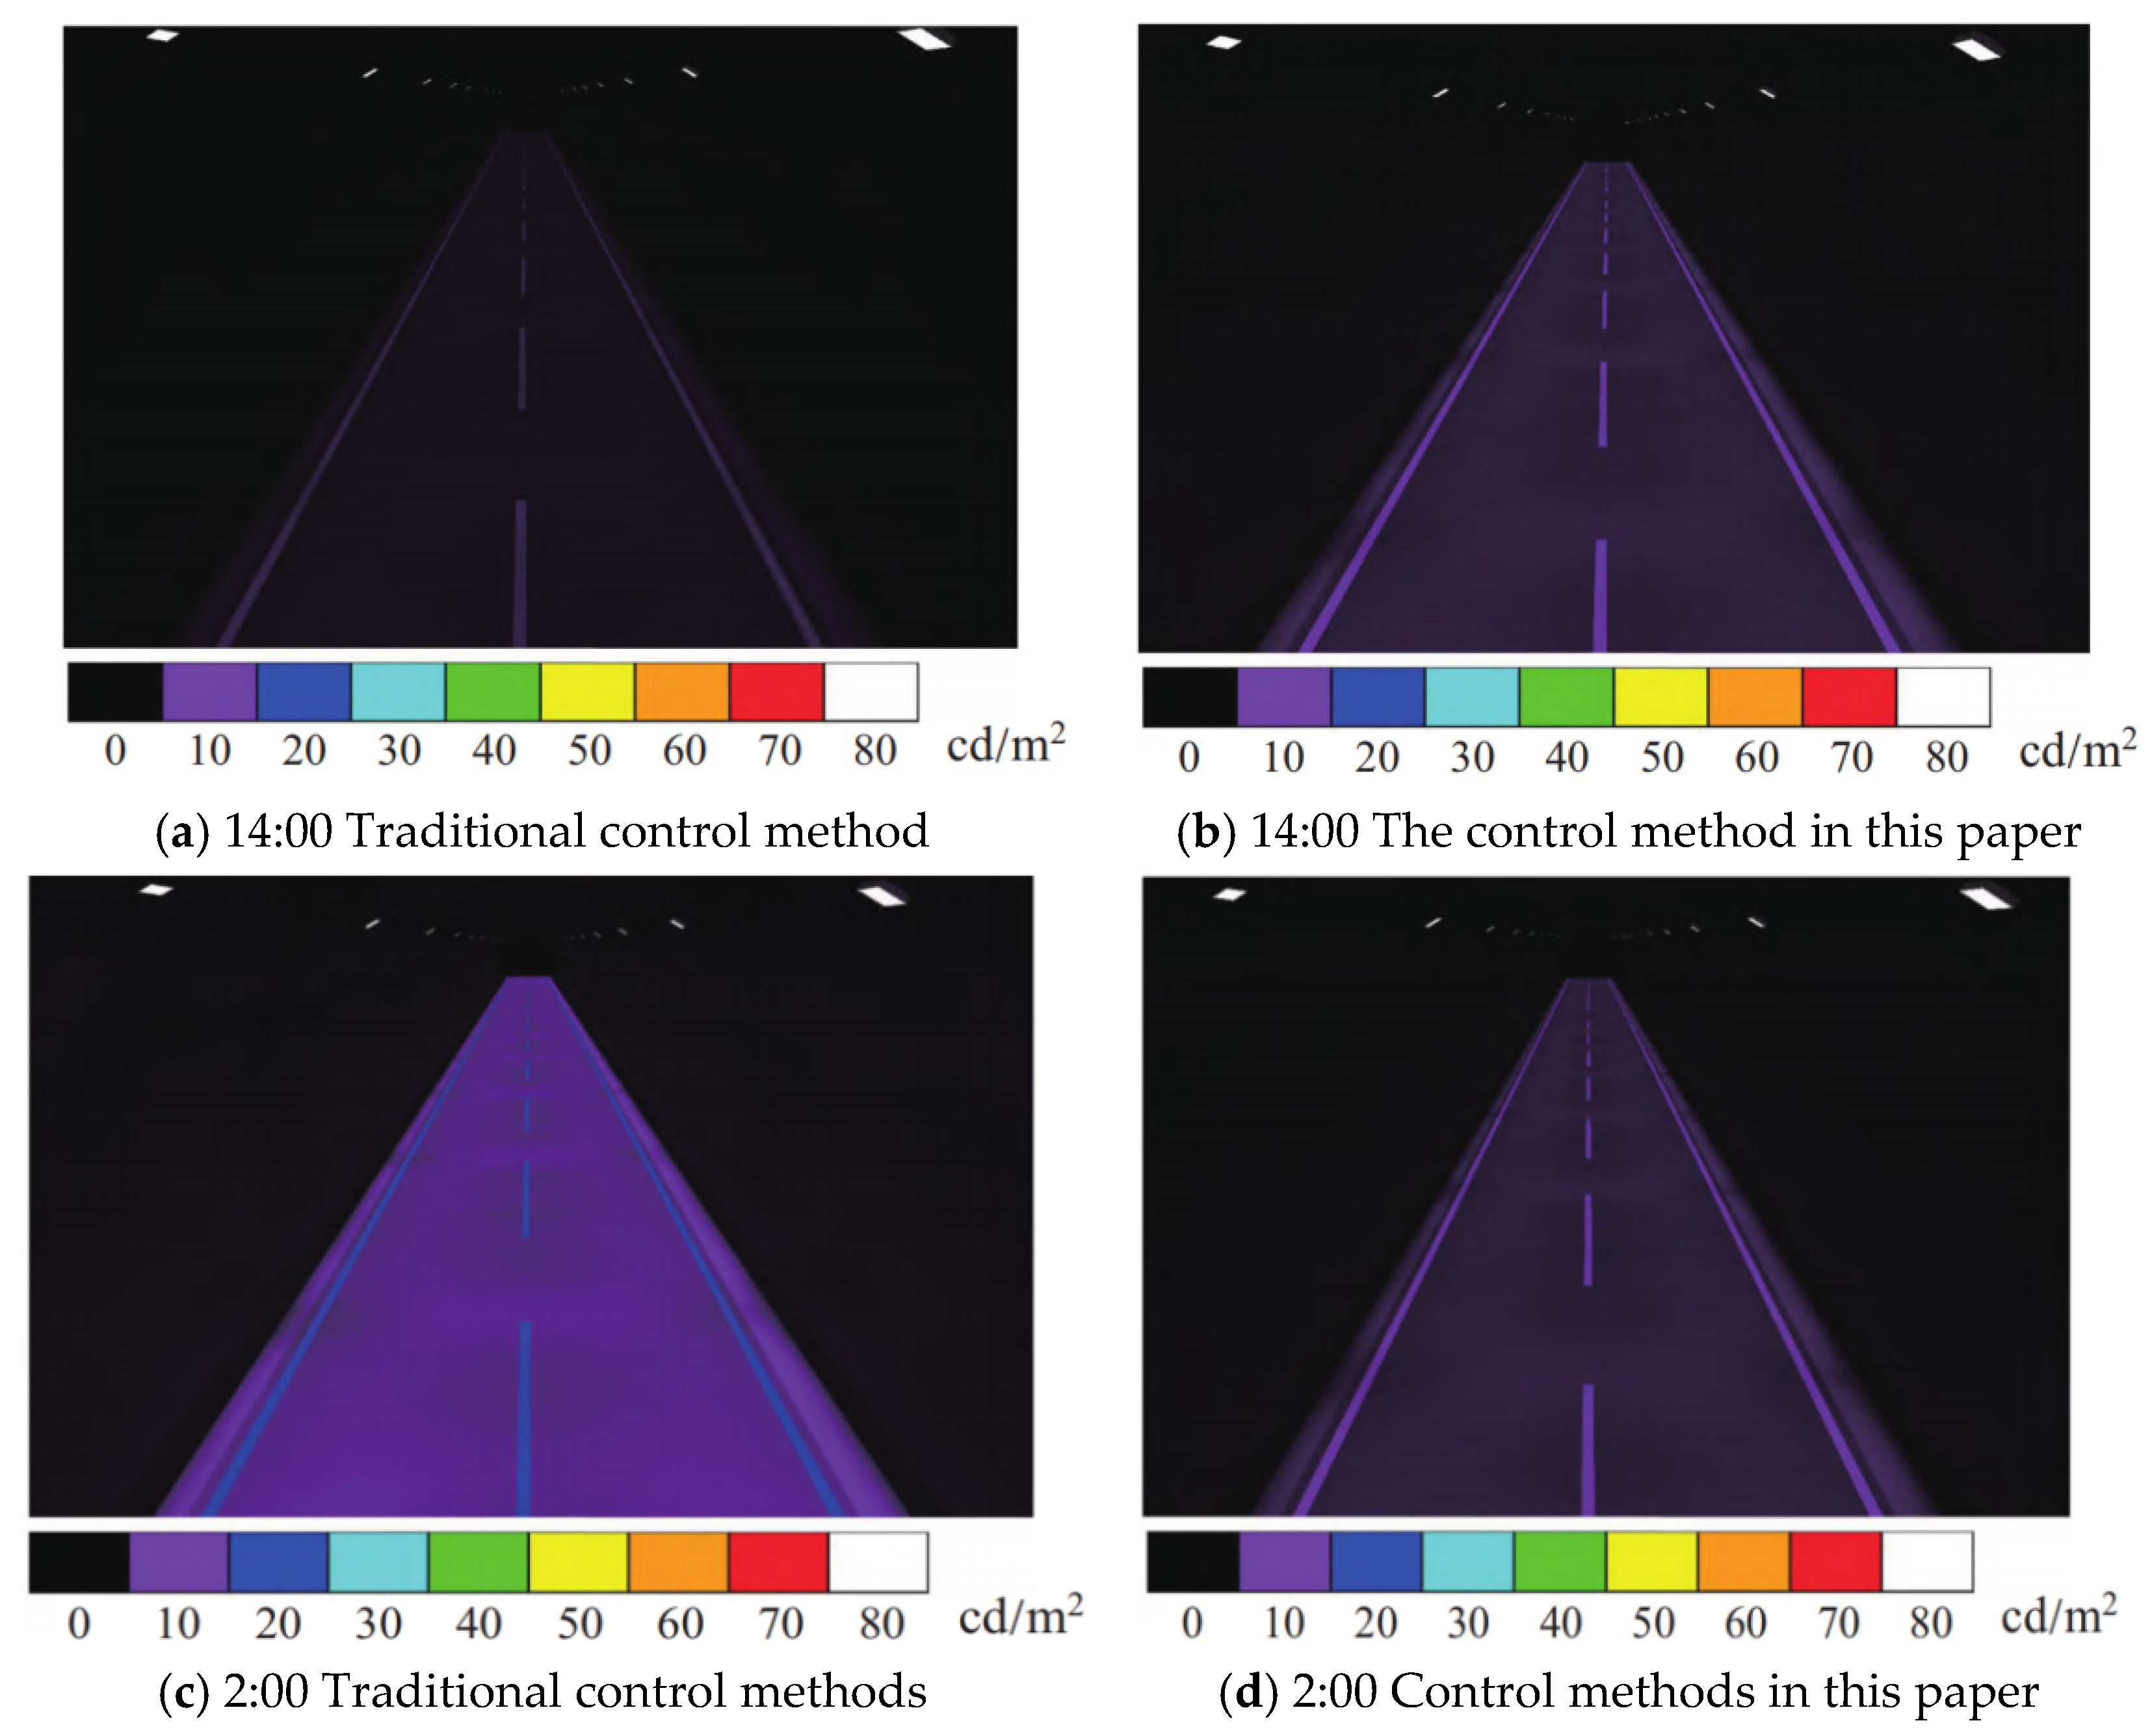
As shown in
Figure 9, traditional control methods applied to the experimental tunnel resulted in an average pavement luminance of only 0.30 cd/m
2 at 14:00. However, at 2:00, the average pavement luminance increased to 1.73 cd/m
2, exceeding the target level and resulting in unnecessary energy consumption. With the proposed dynamic optimization and intelligent control method, pavement luminance remained close to the design target under different operating conditions, while the overall luminance uniformity remained above 0.40. In addition, the proposed method reduced energy consumption by 34.1% under high-visibility conditions. These results demonstrate that the proposed method improves lighting-quality compliance while reducing unnecessary energy consumption. The corresponding lighting-performance and energy-consumption results are summarized in
Table 8.
4.5. Ablation Study
Controlled ablations quantified the contributions of visibility compensation, adaptive fuzzy rules, and the hierarchical FRBF representation. All learning-based variants used the same 99/25 split, training-set preprocessing bounds, 80-rule definition, and five initializations (seeds 2024–2028).
Every controller was evaluated on the same 48 half-hour SUMO–DIALux conditions. The low-visibility subset contains 24 intervals with V < 300 m; compliance is the percentage simultaneously satisfying Lmin ≥ 0.40 cd/m
2 and U
0 ≥ 0.40. In the high-visibility subset (V > 1000 m), energy reduction is (Econv − Evariant)/Econv × 100% relative to conventional Q–v dimming. These are lighting-quality and energy indicators, not direct measures of driving safety. The prediction-accuracy results of the ablation study are summarized in
Table 9.
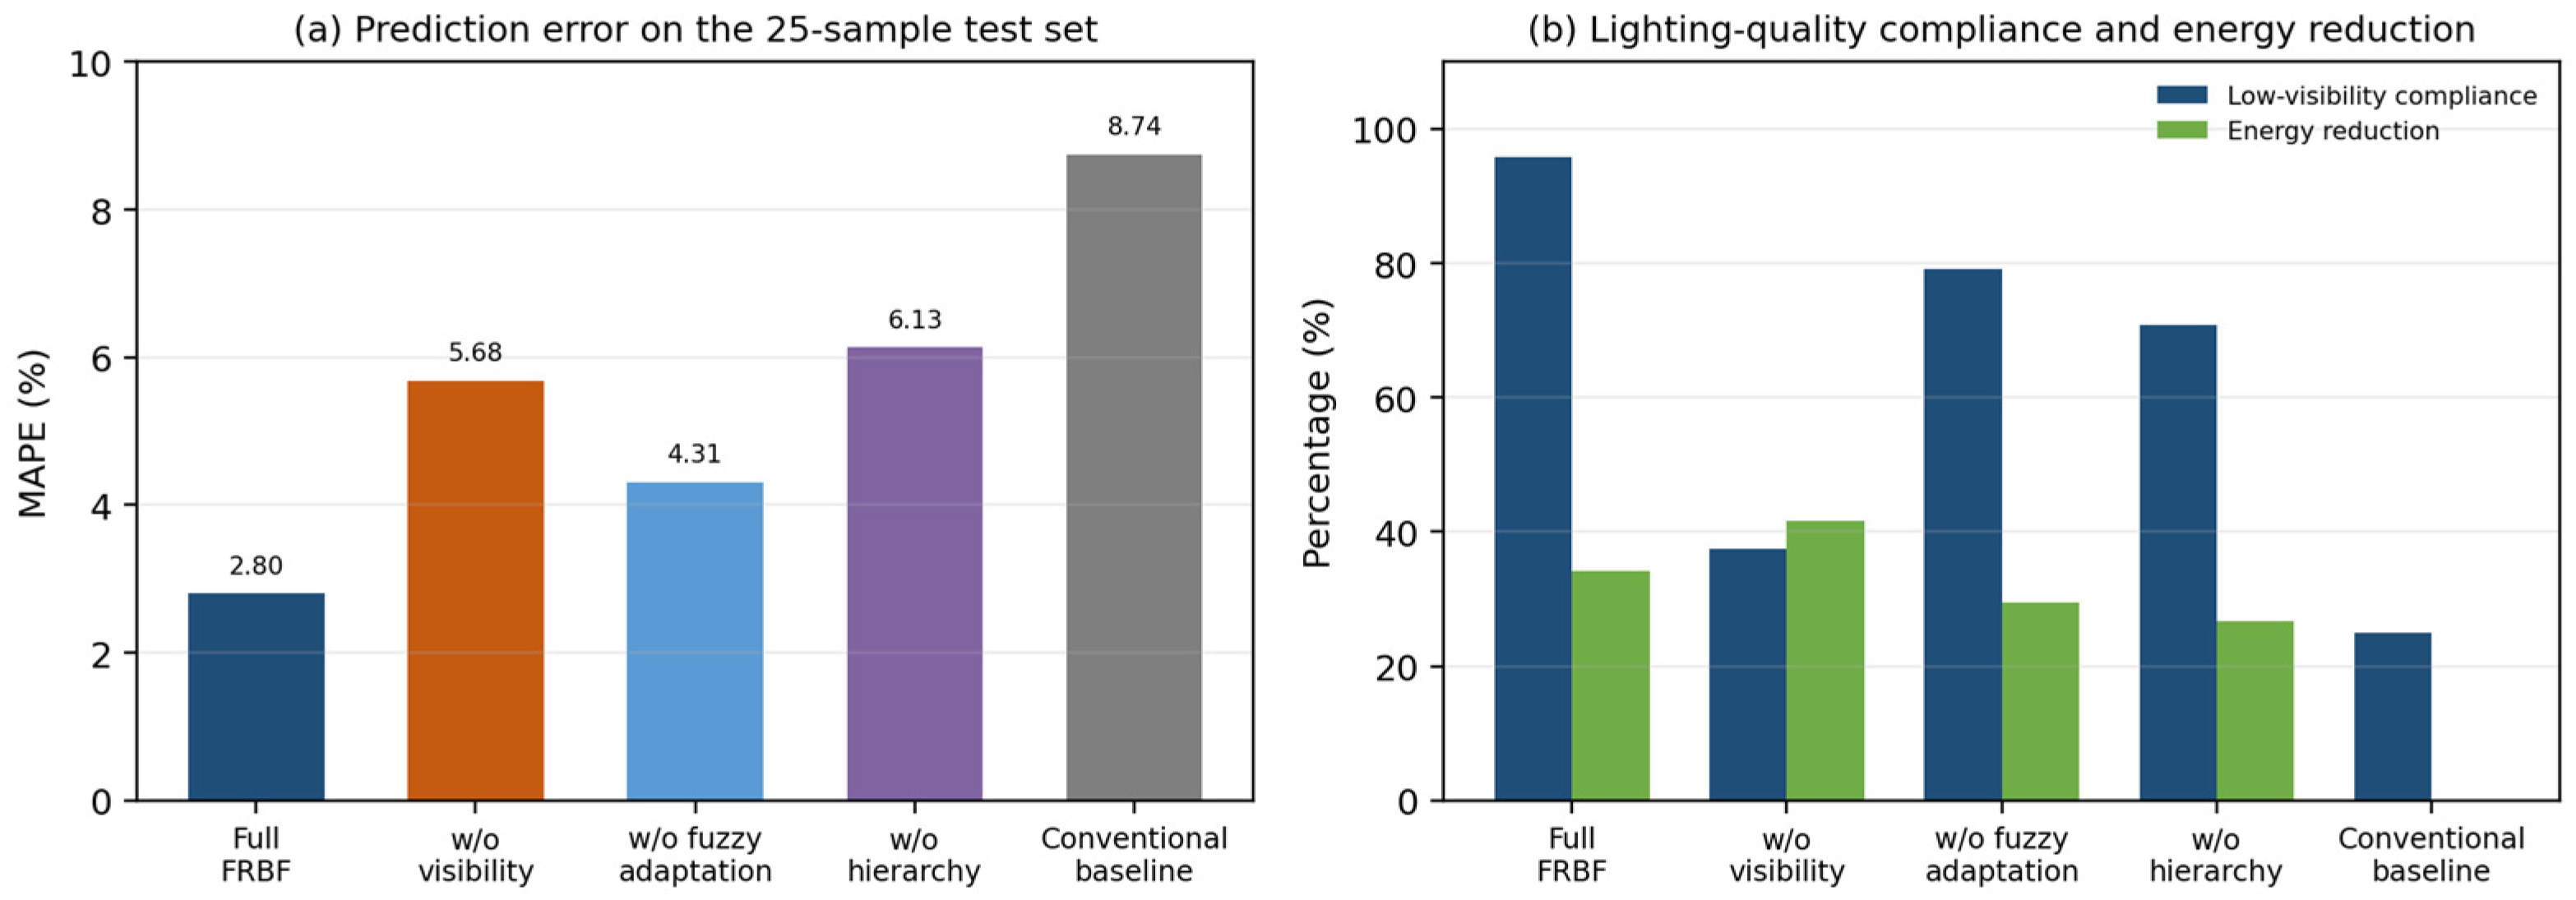
Figure 10 compares the prediction error, low-visibility luminance compliance, and high-visibility energy reduction of the different ablation variants.
Table 10 shows that the full FRBF model produced the lowest prediction error (MAPE = 2.80%) and the highest agreement with the optimized target (R
2 = 0.9924). Removing visibility compensation increased MAPE to 5.68% and RMSE to 0.291 cd/m
2, while replacing adaptive fuzzy rules with fixed rules increased MAPE to 4.31%. Removing the hierarchical FRBF representation caused the largest loss of generalization among the learning-based variants (MAPE = 6.13%). Because every variant uses the same held-out samples and preprocessing protocol, these differences isolate the simulated contribution of each component rather than changes in data partitioning.
The time-series results in
Table 10 clarify the accuracy–energy trade-off. The full controller achieved 95.8% low-visibility luminance compliance, compared with 37.5% when visibility compensation was removed. Although A1 reports a larger nominal energy reduction (41.6%), this outcome is caused by under-lighting: its minimum luminance and uniformity fall to 0.19 cd/m
2 and 0.28, respectively. It therefore cannot be treated as a superior control solution. The full model instead preserves the target luminance and uniformity while reducing high-visibility energy use by 34.1% relative to the conventional baseline.
Taken together, the ablation results support the following bounded conclusion: visibility compensation is the dominant component for maintaining simulated low-visibility lighting quality, whereas adaptive fuzzy rules and the hierarchical FRBF structure improve prediction consistency under changing operating conditions. The present evidence supports improved lighting-quality compliance and energy performance in the simulated scenarios.
5. Conclusions
This study systematically investigates highway tunnel lighting systems with dual objectives of “lighting-quality improvement” and “energy efficiency”. Through field measurements, model development, algorithm optimization, and simulation validation, the research focuses on Chongqing Changchong Tunnel. Field tests conducted under sunny, overcast, and rainy conditions revealed three key findings: (1) tunnel visibility shows a significant positive correlation with pavement brightness; (2) the rate of brightness increase slows down as visibility improves and stabilizes beyond a critical threshold; (3) nighttime visibility exceeds daytime levels, while rainy days outperform overcast conditions. These results confirm that traditional fixed-brightness design fails to meet dynamic spatiotemporal requirements in modern transportation systems.
Based on the “Code for Design of Highway Tunnel Lighting”, two core models are developed: The first is an energy-saving lighting brightness calculation model that integrates traffic flow and speed, which dynamically outputs target road surface brightness. The second incorporates a visibility-based dynamic luminance compensation model with visibility compensation. Its lighting brightness loss rate fitting curve achieves a coefficient of determination of 0.958 with error control within 5(%), enabling precise compensation for brightness loss under low-visibility conditions and forming a “on-demand lighting” dynamic optimization solution.
By integrating 124 sets of real-world tunnel data from various regions and 80 typical lighting scenarios, we developed a fuzzy radial basis function (FRBF) neural network control model. Using 80(%) of the data (99 sets) as training and 25 samples as an independent test set, the model achieved an R2 coefficient of 0.9924, root mean square error (RMSE) of 0.1691, and an average relative error of just 2.8(%) in brightness control. This system meets real-time control precision requirements without requiring hardware modifications.
Through validation using SUMO traffic flow simulation and DIALux 3D tunnel models, the proposed method reduces the standard deviation of tunnel roadway brightness from 0.47 cd/m2 in conventional solutions to 0.09 cd/m2, achieving stable compliance with the 1.0 cd/m2 design standard. It achieves a 95.8% lighting-quality compliance rate under low-visibility conditions and 34.1% energy savings in high-visibility scenarios, demonstrating the method’s effectiveness in improving lighting quality and energy efficiency. Future research should expand data coverage by incorporating lighting data from different regions, various tunnel types, and climate conditions to further enhance the method’s universality and robustness.
Author Contributions
D.X.; methodology, D.X., L.Z. and Q.L.; data curation, L.Z.; investigation, D.X., L.Z. and Q.L.; resources, Q.L.; validation, L.Z. and Q.L.; supervision, D.X.; writing—original draft preparation, D.X.; writing—review and editing, L.Z. and Q.L. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the Department of Education of Jilin Province under Grant No. JJKH20250512KJ.
Data Availability Statement
The data presented in this study are available from the corresponding author upon reasonable request.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Zhou, Y.; Zhu, H.; Feng, S. Analysis of concept and calculation of highway tunnel visibility and smoke concentration. J. Highw. Transp. Res. Dev. 2013, 30, 152–158. [Google Scholar]
- Lu, X.; Li, X.; Qin, W. Retrieval of horizontal distribution of aerosol mass concentration by micro pulse lidar. Opt. Precis. Eng. 2017, 25, 1697–1704. [Google Scholar]
- Weng, J.; Cai, X.; Hu, Y. Analysis of threshold values of contrast revealing coefficient in highway tunnel lighting. Tunn. Undergr. Space Technol. 2019, 92, 103038. [Google Scholar] [CrossRef] [Scilit]
- Dong, L.; Shi, N.; Zhang, L.; Xu, W. Influence of tunnel lighting brightness on visibility under low transmittance. Acta Photonica Sin. 2017, 46, 20–27. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Zhuo, X.; Guo, W.; Wang, X.; Zhao, Z. Lighting environment optimization of highway tunnel entrance based on simulation research. Int. J. Environ. Res. Public Health 2019, 16, 2195. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Angel, P.; Dessislava, P. Optimization of the light distribution of luminaries for tunnel and street lighting. Eng. Optim. 2008, 40, 47–65. [Google Scholar] [CrossRef] [Scilit]
- Li, S.; Tu, G.; Zhou, Q. An optimal design model for tunnel lighting systems. Optik 2020, 226, 165660. [Google Scholar] [CrossRef] [Scilit]
- Zhang, D.; Hong, Y.; Zhou, Y. Research of optimization design and calculation method of illumination of highway tunnels. Tunn. Constr. 2017, 37, 803–807. [Google Scholar]
- Li, N.; Wang, X.; Wu, J.; Huang, G.; Shao, Z. Using of genetic algorithms in highway tunnel lighting intelligent optimization. J. Cent. South Univ. (Sci. Technol.) 2013, 44, 342–345. [Google Scholar]
- Carni, D.L.; Grimaldi, D.; Lamonaca, F.; Martirano, L.; Parise, G. A smart control to operate the lighting system in the road tunnels. In The 7th International Conference on Intelligent Data Acquisition and Advanced Computing Systems (IDAACS2013); IEEE: Berlin, Germany, 2013; pp. 786–790. [Google Scholar]
- Li, X.; Tang, B.; Zeng, C. Transient analysis of the driving behavior in the dumpling fog sections of expressway based on catastrophe theory. China J. Highw. Transp. 2018, 31, 78–87. [Google Scholar]
- Mehri, A.; Sajedifar, J.; Abbasi, M.; Naimabadi, A.; Mohammadi, A.A.; Teimori, G.H.; Zakerian, S.A. Safety evaluation of lighting at very long tunnels on the basis of visual adaptation. Saf. Sci. 2019, 116, 196–207. [Google Scholar] [CrossRef] [Scilit]
- Lai, W.; Liu, X.; Chen, W.; Lei, X.; Cheng, X. Light intensity distribution optimization for tunnel lamps in different zones of a long tunnel. Opt. Express 2014, 22, 22952–22961. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Han, L. Optimization Design and Analysis of Highway Tunnel Lighting Systems. Transp. World 2023, 15, 153–155. [Google Scholar] [CrossRef]
- Qin, L.; Dong, L.; Xu, W.; Zhang, L.; Yan, Q.; Chen, X. A “vehicle in, light brightens; vehicle out, light darkens” energy-saving control system of highway tunnel lighting. Tunn. Undergr. Space Technol. 2017, 66, 147–156. [Google Scholar] [CrossRef] [Scilit]
- JTG/T D70/2-01-2014; Guidelines for Design of Lighting of Highway Tunnels. Ministry of Transport of the People’s Republic of China: Beijing, China, 2014.
- Zhang, K.; He, Y.; Zhang, Y.; Guo, H.; Yang, B.; Fu, D.; Wen, R.; Zhang, M.; Li, Y.; Wang, J. A Dynamic Optimization Method for Tunnel Brightness Control: System, Terminal, and Medium. Chinese Patent CN119150027A, 17 December 2024. [Google Scholar] [PubMed]
- Li, S. An optimal model for tunnel lighting control systems. Tunn. Undergr. Space Technol. 2015, 49, 328–335. [Google Scholar] [CrossRef] [Scilit]
- Musa, M.S.; Nallagownden, P.; Chiu, K.W.; Sarwar, M.B. Design and development of intelligent adaptive tunnel lighting system. In Conference on Energy Conversion (CENCON); IEEE: Johor, Malaysia, 2015; pp. 289–292. [Google Scholar]
- Zhao, L.; Qu, S.; Zhang, W. Design of multi-channel data collector for highway tunnel lighting based on STM32 and modbus protocol. Optik 2020, 213, 164388. [Google Scholar] [CrossRef] [Scilit]
- Zhao, J.D.; Feng, Y.Z.; Yang, C. Intelligent control and energy saving evaluation of highway tunnel lighting: Based on three-dimensional simulation and long short-term memory optimization algorithm. Tunn. Undergr. Space Technol. 2021, 109, 103768. [Google Scholar] [CrossRef] [Scilit]
- Niu, J.; Liang, B.; He, S.; Xiao, J.; Qin, C. Long tunnel lighting environment improvement method based on multiple-parameter intelligent control: Considering dynamic changes in luminance difference. Tunn. Undergr. Space Technol. 2022, 128, 104637. [Google Scholar] [CrossRef] [Scilit]
- Wang, H.; Chen, Y.; Cai, Y.; Chen, L.; Li, Y.; Sotelo, M.A.; Li, Z. SFNet-N: An Improved SFNet Algorithm for Semantic Segmentation of Low-Light Autonomous Driving Road Scenes. IEEE Trans. Intell. Transp. Syst. 2022, 23, 21405–21417. [Google Scholar] [CrossRef] [Scilit]
Figure 1.
Location and lighting environment of test tunnel.
Figure 1.
Location and lighting environment of test tunnel.
Figure 2.
Illuminance distribution of each lighting area in highway tunnel under different space–time conditions.
Figure 2.
Illuminance distribution of each lighting area in highway tunnel under different space–time conditions.
Figure 3.
Correlation between road brightness and visibility in tunnel under different space–time conditions.
Figure 3.
Correlation between road brightness and visibility in tunnel under different space–time conditions.
Figure 4.
Intelligent control flow.
Figure 4.
Intelligent control flow.
Figure 5.
Relationship between tunnel visibility, road brightness and lighting brightness loss rate.
Figure 5.
Relationship between tunnel visibility, road brightness and lighting brightness loss rate.
Figure 6.
Schematic diagram of FRBF-Based Real-Time Intelligent Control Model.
Figure 6.
Schematic diagram of FRBF-Based Real-Time Intelligent Control Model.
Figure 7.
Relative error of neural network algorithm.
Figure 7.
Relative error of neural network algorithm.
Figure 8.
Comparative analysis of new dimming scheme and traditional scheme.
Figure 8.
Comparative analysis of new dimming scheme and traditional scheme.
Figure 9.
Pseudo-color map of the middle section of the tunnel at different times.
Figure 9.
Pseudo-color map of the middle section of the tunnel at different times.
Figure 10.
Simulated ablation comparison. (a) Prediction error on the identical independent test set; (b) low-visibility luminance compliance and high-visibility energy reduction relative to the conventional Q–v controller.
Figure 10.
Simulated ablation comparison. (a) Prediction error on the identical independent test set; (b) low-visibility luminance compliance and high-visibility energy reduction relative to the conventional Q–v controller.
Table 1.
Composition and source of the lighting-control dataset.
Table 1.
Composition and source of the lighting-control dataset.
| Tunnel/Dataset | Region | Measurement Period | Operating Conditions | No. of Samples | Use |
|---|
| Changchong Tunnel | Chongqing, China | Mar. 2024 | Sunny, overcast, rainy; day/night | 48 | Training & test |
| Longquan Tunnel | Sichuan, China | Apr.–May 2024 | Clear and overcast; moderate traffic | 31 | Training |
| Shuigang Tunnel | Guizhou, China | Jun. 2024 | Rainy and foggy; variable traffic | 45 | Training & test |
| total | | | | 124 | Training & Test |
Table 2.
Measurement instruments and data-quality configuration.
Table 2.
Measurement instruments and data-quality configuration.
| Variable | Instrument/Method | Model | Range | Accuracy | Sampling Interval |
|---|
| Visibility | Forward-scatter visibility meter | Vaisala PWD22 | 10–2000 m | ±10% (≤1000 m) | 30 min |
| Traffic volume | Video detection/loop count | Hikvision iDS-TCV900 | 0–2400 veh/h/lane | ±3% | 30 min |
| Vehicle speed | Microwave radar detector | Smartmicro UMRR-11 | 0–160 km/h | ±1 km/h | 30 min |
| Pavement luminance | Portable luminance meter | Konica Minolta LS-160 | 0.01–999,900 cd/m2 | ±2% | 30 min |
| Current lighting intensity | Dimming controller log | 0–10 V LED driver | 0–100% | ±1% | 30 min |
Table 3.
FRBF input variables and rule configuration.
Table 3.
FRBF input variables and rule configuration.
| Input Variable | Physical Range | Norm Method | Membership-Function Type | No. of Fuzzy Sets | Linguistic Labels |
|---|
| 10–2000 m | Min–max to [0, 1] | Gaussian | 5 | Very low, low, medium, high, very high |
| Q | 0–2400 veh/h/lane | Min–max to [0, 1] | Gaussian | 4 | Low, medium, high, very high |
| v | 20–100 km/h | Min–max to [0, 1] | Gaussian | 4 | Low, medium, high, very high |
| 0.50–2.00 cd/m2 | Output scaling | Zero-order T–S consequent | — | Optimized luminance level |
| Total | — | — | — | 80 rules | 5 × 4 × 4 operating-state combinations |
Table 4.
FRBF training and implementation settings.
Table 4.
FRBF training and implementation settings.
| Setting | Value |
|---|
| Training samples | 99 |
| Test samples | 25 |
| Maximum iterations | 1000 |
| Target training-error threshold | 0.01 |
| Training/optimization algorithm | Hybrid least-squares/gradient descent |
| Learning rate/step size | 0.01; adaptive decay factor 0.95 |
| Initialization method | k-means centers; random consequent weights |
| Random seed for split | 2024 |
| Input normalization | Min–max normalization to [0, 1] (training-set bounds) |
| Software and version | MATLAB R2023b; Fuzzy Logic Toolbox |
Table 5.
Prediction performance of the FRBF model on the independent test set.
Table 5.
Prediction performance of the FRBF model on the independent test set.
| Metric | Evaluation Set | Value |
|---|
| R2 | 25-sample test set | 0.9924 |
| RMSE (cd/m2) | 25-sample test set | 0.1691 |
| MAE (cd/m2) | 25-sample test set | 0.1127 |
| MAPE (%) | 25-sample test set | 2.80 |
Table 6.
SUMO simulation and calibration settings.
Table 6.
SUMO simulation and calibration settings.
| Setting | Value |
|---|
| Validation period | March 2024 |
| Simulation duration | 24 h |
| Output interval | 30 min |
| Number of time points | 48 |
| Traffic input source | Field measurements |
| Car-following model | Krauss model (tau = 1.0 s; sigma = 0.5) |
| Lane-changing model | LC2013 default model; keep-right enabled |
| Vehicle composition | Passenger cars 82%; trucks 13%; buses 5% |
| Speed distribution/calibration | Truncated normal; mean and SD matched by 30 min interval |
| Other calibration parameters | 2 lanes/direction; speed limit 80 km/h; 3 simulation replications |
Table 7.
DIALux simulation model and luminaire parameters.
Table 7.
DIALux simulation model and luminaire parameters.
| Setting | Value |
|---|
| Tunnel geometry source | As-built drawings of Changchong Tunnel |
| Tunnel length (m) | 1120 |
| Tunnel width (m) | 10.5 |
| Luminaire model | LED tunnel luminaire, asymmetric optics |
| Rated power (W) | 120 |
| Luminous flux (lm) | 15,600 |
| Mounting height (m) | 5.5 |
| Luminaire spacing (m) | 8.0 |
| Sidewall reflectance | 0.05 |
| Ceiling reflectance | 0.05 |
| Pavement reflectance | 0.18 |
| External luminance range (cd/m2) | 0–2646.03 |
Table 8.
Comparison of lighting performance under different control methods.
Table 8.
Comparison of lighting performance under different control methods.
| Condition | Control Method | Average Luminance | Minimum Luminance | Overall Uniformity U0 | Energy Consumption |
|---|
| 14:00 | Conventional | 0.30 | 0.08 | 0.27 | 52.8 |
| 14:00 | Proposed | 1.02 | 0.43 | 0.42 | 34.8 |
| 2:00 | Conventional | 1.73 | 0.65 | 0.38 | 61.2 |
| 2:00 | Proposed | 1.01 | 0.42 | 0.41 | 40.3 |
Table 9.
Prediction-accuracy ablation on the identical 25-sample independent test set (simulated mean ± standard deviation; n = 5).
Table 9.
Prediction-accuracy ablation on the identical 25-sample independent test set (simulated mean ± standard deviation; n = 5).
| Variant | Visibility Compensation | Adaptive Fuzzy Rules | Hierarchical FRBF | R2 | RMSE
(cd/m2) | MAPE
(%) |
|---|
| Full proposed FRBF | Yes | Yes | Yes | 0.9924 ± 0.0011 | 0.169 ± 0.013 | 2.80 ± 0.25 |
| A1: w/o visibility compensation | No | Yes | Yes | 0.9786 ± 0.0024 | 0.291 ± 0.019 | 5.68 ± 0.42 |
| A2: w/o adaptive fuzzy rules | Yes | No | Yes | 0.9841 ± 0.0020 | 0.243 ± 0.016 | 4.31 ± 0.37 |
| A3: w/o hierarchical FRBF | Yes | Yes | No | 0.9718 ± 0.0031 | 0.329 ± 0.022 | 6.13 ± 0.48 |
Table 10.
Operating-performance ablation under the common 48-condition SUMO–DIALux sequence (simulated values).
Table 10.
Operating-performance ablation under the common 48-condition SUMO–DIALux sequence (simulated values).
| Controller | Average Luminance (cd/m2) | Minimum Luminance (cd/m2) | Uniformity U0 | Low-Visibility Compliance (%) | High-Visibility Energy Reduction (%) |
|---|
| Full proposed FRBF | 1.01 | 0.42 | 0.41 | 95.8 | 34.1 |
| A1: w/o visibility compensation | 0.70 | 0.19 | 0.28 | 37.5 | 41.6 |
| A2: w/o adaptive fuzzy rules | 0.91 | 0.33 | 0.36 | 79.2 | 29.4 |
| A3: w/o hierarchical FRBF | 0.88 | 0.31 | 0.34 | 70.8 | 26.7 |
| Conventional Q–v dimming baseline | 0.63 | 0.16 | 0.23 | 25.0 | 0.0 |
| Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |