A Skeleton-Line-Based Spiral Coverage Path Planning Method for UAV Inspection of Three-Dimensional Structures


Abstract
1. Introduction
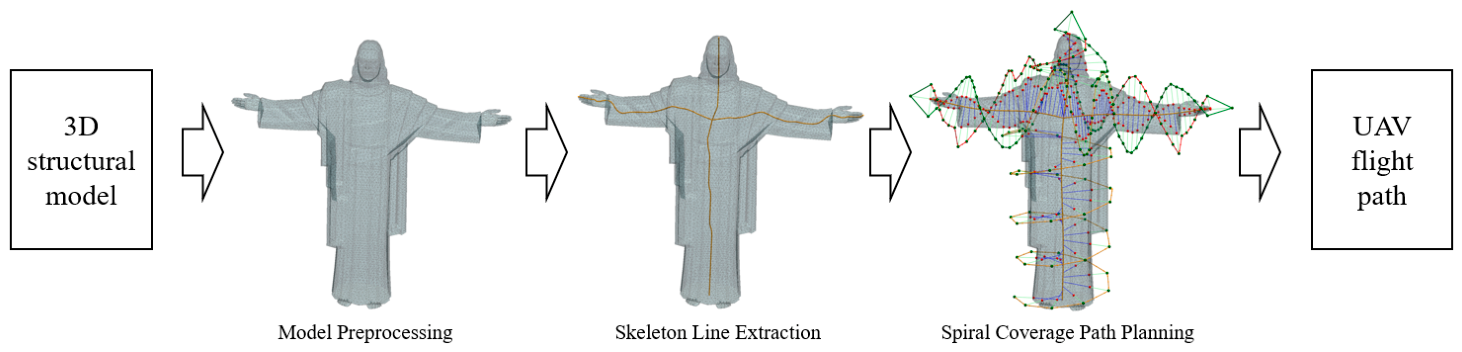
- A skeleton-guided coverage path planning framework is proposed for UAV inspection of three-dimensional structures. Unlike conventional methods that first generate an unordered set of candidate viewpoints and then solve a separate path sequencing problem, the proposed method uses the one-dimensional skeleton line as a geometric and topological guide to generate viewpoints and coverage paths, which to some extent reduces the dependence on global combinatorial optimization.
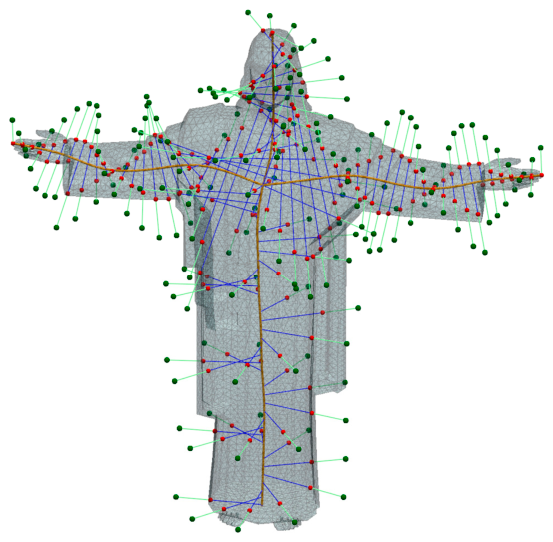
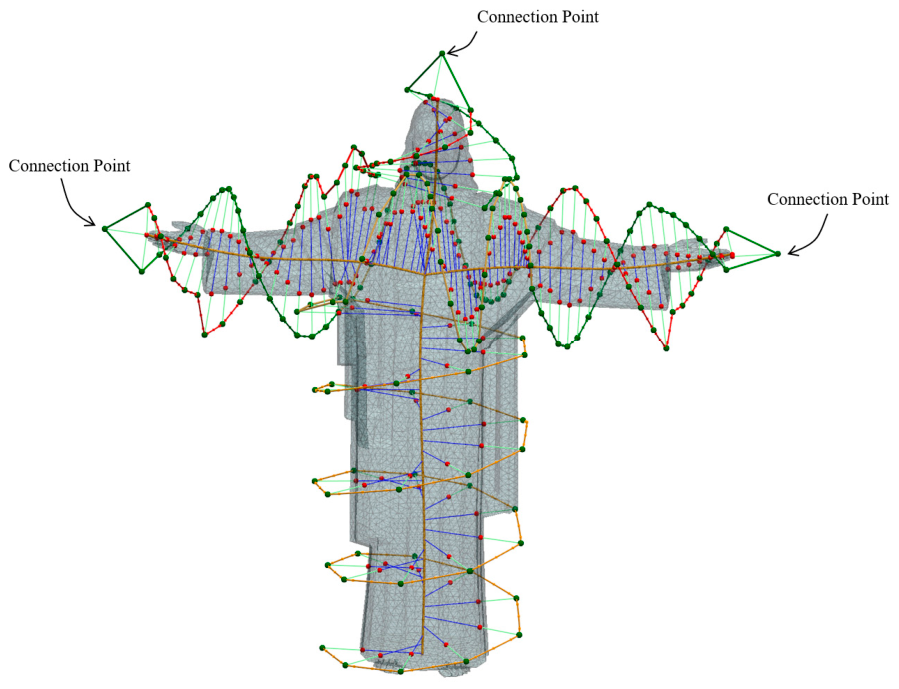
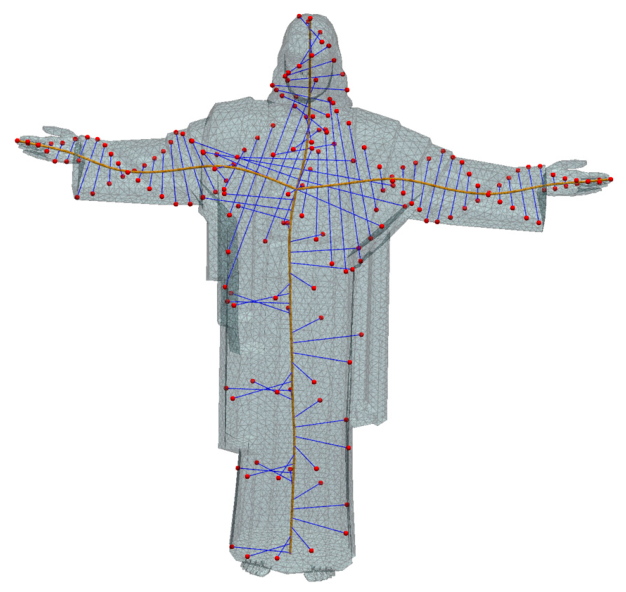
- A spiral-guided viewpoint generation strategy based on rotating radial sampling is developed. Sampling points are first distributed along the extracted skeleton curve. At each sampling point, rotating radial rays are constructed on the plane perpendicular to the local skeleton direction and intersected with the mesh surface to obtain surface sampling points. UAV viewpoints are then generated by offsetting these surface points according to the predefined viewing distance. Since the generated viewpoints naturally follow a spiral order, the coverage path can be constructed directly according to the sampling sequence.
2. Problem Statement
3. Skeleton-Guided Spiral Coverage Path Planning Method
3.1. Model Preprocessing
3.2. Skeleton Line Extraction
3.3. Spiral Coverage Path Planning Based on Skeleton Line
3.3.1. Spiral-Guided Viewpoint Generation
- (1)
- Sampling point generation along a skeleton curve.
- (2)
- Sampling point generation on the mesh surface.
- (3)
- Viewpoint generation based on mesh surface sampling points.
3.3.2. Spiral Coverage Path Construction
4. Experiment and Discussion
4.1. Simulation Setup, Parameter Sensitivity Analysis, and Feasibility Verification
4.2. Comparison with Existing Methods
5. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
Abbreviations
| 3D | Three Dimensional |
| UAV | Unmanned Aerial Vehicle |
| CPP | Coverage Path Planning |
| VPP | Viewpoint Planning |
| TSP | Traveling Salesman Problem |
| GA | Genetic Algorithm |
| ACO | Ant Colony Optimization |
| ACO−VP | Ant Colony Optimization algorithm with Variable Pheromones |
| ACO−OPD | Ant colony optimization-optimized parameter distribution |
| FOV | Field of View |
References
- Cacciuttolo, C.; Muñoz, E.; Sotil, A. Technological evolution of architecture, engineering, construction, and structural health monitoring of bridges in peru: History, challenges, and opportunities. Appl. Sci. 2025, 15, 831. [Google Scholar] [CrossRef] [Scilit]
- Rakha, T.; Gorodetsky, A. Review of unmanned aerial system (UAS) applications in the built environment: Towards automated building inspection procedures using drones. Autom. Constr. 2018, 93, 252–264. [Google Scholar] [CrossRef] [Scilit]
- Halder, S.; Afsari, K. Robots in inspection and monitoring of buildings and infrastructure: A systematic review. Appl. Sci. 2023, 13, 2304. [Google Scholar] [CrossRef] [Scilit]
- Zheng, J.; Tan, J.; Chen, G. Research on UAV coverage path planning in building visual inspection. J. Build. Eng. 2025, 111, 113556. [Google Scholar] [CrossRef] [Scilit]
- Del Savio, A.A.; Luna Torres, A.; Chicchón Apaza, M.A.; Vergara Olivera, M.A.; Llimpe Rojas, S.R.; Urday Ibarra, G.T.; Reyes Ñique, J.L.; Macedo Arevalo, R.I. Integrating a LiDAR sensor in a UAV platform to obtain a georeferenced point cloud. Appl. Sci. 2022, 12, 12838. [Google Scholar] [CrossRef] [Scilit]
- Jaakkola, A.; Hyyppä, J.; Kukko, A.; Yu, X.; Kaartinen, H.; Lehtomäki, M.; Lin, Y. A low-cost multi-sensoral mobile mapping system and its feasibility for tree measurements. ISPRS J. Photogramm. Remote Sens. 2010, 65, 514–522. [Google Scholar] [CrossRef] [Scilit]
- Aggarwal, S.; Kumar, N. Path planning techniques for unmanned aerial vehicles: A review, solutions, and challenges. Comput. Commun. 2020, 149, 270–299. [Google Scholar] [CrossRef] [Scilit]
- Kumar, K.; Kumar, N. Region coverage-aware path planning for unmanned aerial vehicles: A systematic review. Phys. Commun. 2023, 59, 102073. [Google Scholar] [CrossRef] [Scilit]
- Zhang, N.; Yue, L.; Zhang, Q.; Gao, C.; Zhang, B.; Wang, Y. A UAV coverage path planning method based on a diameter–height model for mountainous terrain. Appl. Sci. 2025, 15, 1988. [Google Scholar] [CrossRef] [Scilit]
- Du, J.; Huang, B.; Jia, B. An efficient UAV coverage path planning method for 3-d structures. IEEE Internet Things J. 2025, 12, 31869–31880. [Google Scholar] [CrossRef] [Scilit]
- Khoufi, I.; Laouiti, A.; Adjih, C. A survey of recent extended variants of the traveling salesman and vehicle routing problems for unmanned aerial vehicles. Drones 2019, 3, 66. [Google Scholar] [CrossRef] [Scilit]
- Xu, Y.; Che, C. A brief review of the intelligent algorithm for traveling salesman problem in UAV route planning. In Proceedings of the 2019 IEEE 9th International Conference on Electronics Information and Emergency Communication (ICEIEC), Beijing, China, 12–14 July 2019. [Google Scholar]
- Bui, D.N.; Duong, T.N.; Phung, M.D. Ant colony optimization for cooperative inspection path planning using multiple unmanned aerial vehicles. In Proceedings of the 2024 IEEE/SICE International Symposium on System Integration (SII), Ha Long, Vietnam, 8–11 January 2024; pp. 675–680. [Google Scholar]
- Li, J.; Xiong, Y.; She, J. UAV path planning for target coverage task in dynamic environment. IEEE Internet Things J. 2023, 10, 17734–17745. [Google Scholar] [CrossRef] [Scilit]
- Baniasadi, P.; Foumani, M.; Smith-Miles, K.; Ejov, V. A transformation technique for the clustered generalized traveling salesman problem with applications to logistics. Eur. J. Oper. Res. 2020, 285, 444–457. [Google Scholar] [CrossRef] [Scilit]
- Bircher, A.; Alexis, K.; Burri, M.; Oettershagen, P.; Omar, S.; Mantel, T.; Siegwart, R. Structural inspection path planning via iterative viewpoint resampling with application to aerial robotics. In Proceedings of the 2015 IEEE International Conference on Robotics and Automation (ICRA), Seattle, WA, USA, 26–30 May 2015. [Google Scholar]
- Choi, Y.; Choi, Y.; Briceno, S.; Mavris, D.N. Three-dimensional UAS trajectory optimization for remote sensing in an irregular terrain environment. In Proceedings of the 2018 International Conference on Unmanned Aircraft Systems (ICUAS), Dallas, TX, USA, 12–15 June 2018; pp. 1101–1108. [Google Scholar]
- Jing, W.; Polden, J.; Lin, W.; Shimada, K. Sampling-based view planning for 3d visual coverage task with unmanned aerial vehicle. In Proceedings of the 2016 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Daejeon, Republic of Korea, 9–14 October 2016; pp. 1808–1815. [Google Scholar]
- Zhao, Y.; Lu, B.; Alipour, M. Optimized structural inspection path planning for automated unmanned aerial systems. Autom. Constr. 2024, 168, 105764. [Google Scholar] [CrossRef] [Scilit]
- La Regina, R.; Curcio, M.; Genel, Ö.E.; Pappalardo, C.M. Comparison of two control strategies for a quarter drone system. In New Technologies, Development and Application VII, Cham, 2024; Springer Nature: Cham, Switzerland, 2024. [Google Scholar]
- Szilvśi-Nagy, M.; Mátyási, G. Analysis of STL files. Math. Comput. Model. 2003, 38, 945–960. [Google Scholar] [CrossRef] [Scilit]
- Shimada, K.; Gossard, D.C. Bubble mesh: Automated triangular meshing of non-manifold geometry by sphere packing. In Proceedings of the Third ACM Symposium on Solid Modeling and Applications, Salt Lake City, UT, USA, 17–19 May 1995; Association for Computing Machinery: Salt Lake City, UT, USA, 1995. [Google Scholar]
- Au, O.K.; Tai, C.; Chu, H.; Cohen-Or, D.; Lee, T. Skeleton extraction by mesh contraction. ACM Trans. Graph. (TOG) 2008, 27, 1–10. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Lee, T. Curve-skeleton extraction using iterative least squares optimization. IEEE Trans. Vis. Comput. Graph. 2008, 14, 926–936. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhang, N.; Zhang, L.; Chen, Y.; Shi, Y. Local barycenter based efficient tree-support generation for 3d printing. Comput.-Aided Des. 2019, 115, 277–292. [Google Scholar] [CrossRef] [Scilit]
- Staderini, V.; Glück, T.; Schneider, P.; Mecca, R.; Kugi, A. Surface sampling for optimal viewpoint generation. In Proceedings of the 2023 IEEE 13th International Conference on Pattern Recognition Systems (ICPRS), Guayaquil, Ecuador, 4–7 July 2023; pp. 1–7. [Google Scholar]






| Symbol | Description |
|---|---|
| S | the set of all triangular facets in the mesh model |
| the set of viewpoints | |
| a 3D point in space with three coordinate components | |
| the position of a viewpoint | |
| the viewing direction of a viewpoint | |
| the view distance between a camera position and a target point | |
| and | the horizontal and vertical field-of-view (FOV) angles of a camera |
| the vertex set of a skeleton curve | |
| the sampling interval along the skeleton curve | |
| the angular sampling interval | |
| the initial sampled angular position | |
| the number of sampling points along the skeleton curve | |
| the sampling positions along the skeleton curve | |
| the unit direction vector at sampling point with index k | |
| the radial vector at the sampling point with index k | |
| the orientation angle at the sampling point with index k | |
| a pair of orthogonal basis vectors at the sampling point with index k | |
| the viewpoint position corresponding to the sampling point with index k | |
| the viewpoint direction vector corresponding to the sampling point with index k |
| Models | z mm3) | Triangle Number |
|---|---|---|
| Christ | 38 | 19,383 |
| Wind Turbine | 120 | 8564 |
| Big Ben | 110 | 8668 |
| Index Label | (mm) | (°) | Covered Facets | Uncovered Facets | Coverage Rate | Viewpoints | Path Length (mm) | Time (s) |
|---|---|---|---|---|---|---|---|---|
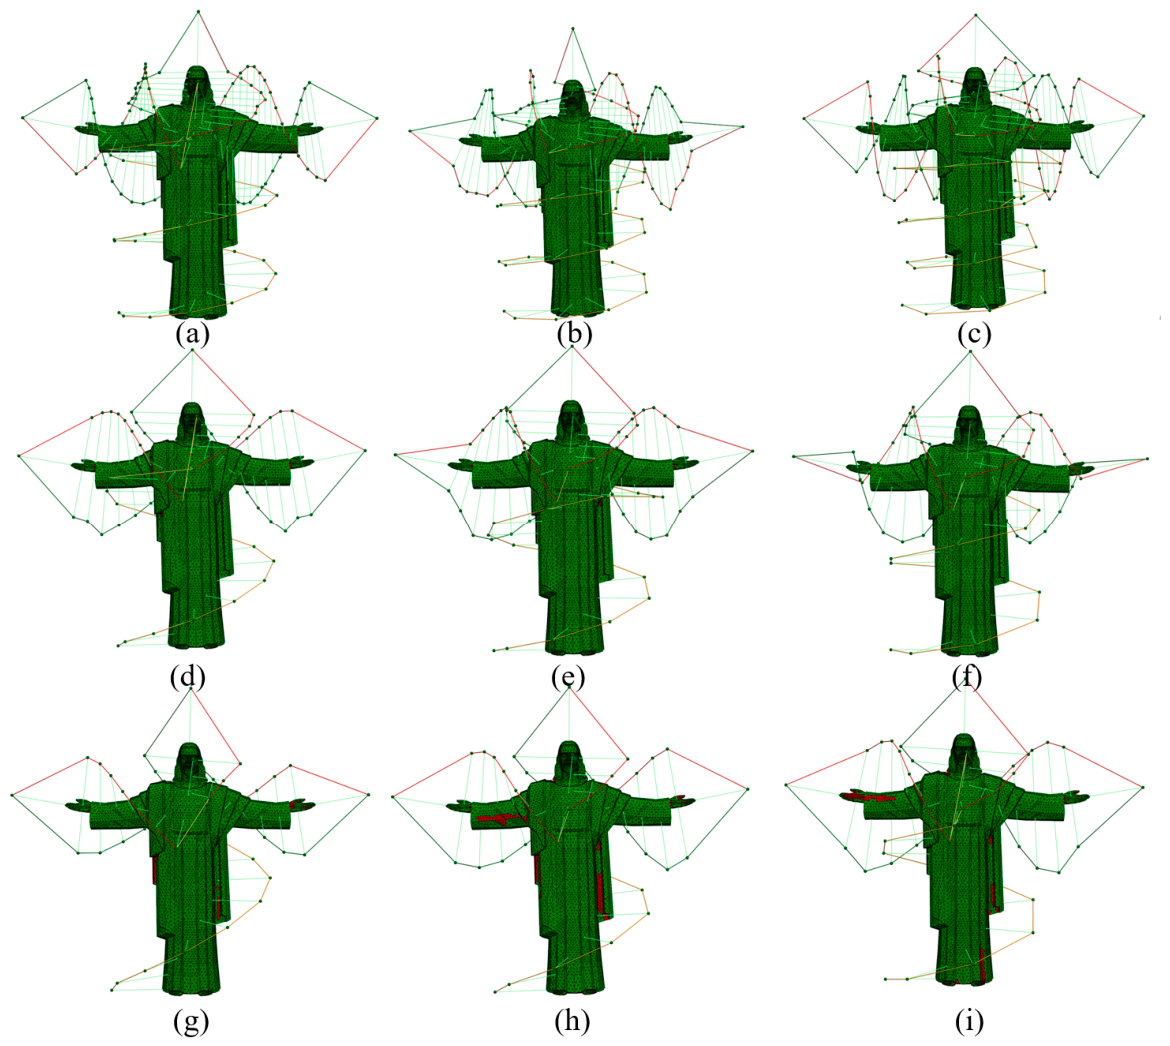
| a | 1 | 30 | 18,865 | 518 | 97.33% | 130 | 535.53 | 13.52 |
| b | 1 | 40 | 18,890 | 493 | 97.46% | 123 | 629.45 | 12.43 |
| c | 1 | 50 | 18,883 | 500 | 97.42% | 125 | 764.47 | 13.66 |
| d | 2 | 30 | 18,796 | 587 | 96.97% | 83 | 346.42 | 10.19 |
| e | 2 | 40 | 18,728 | 655 | 96.62% | 78 | 334.32 | 8.73 |
| f | 2 | 50 | 18,700 | 683 | 96.48% | 75 | 432.39 | 11.37 |
| g | 3 | 30 | 17,406 | 1977 | 89.80% | 48 | 282.01 | 8.45 |
| h | 3 | 40 | 17,193 | 2190 | 88.70% | 45 | 294.48 | 7.23 |
| i | 3 | 50 | 17,552 | 1831 | 90.55% | 48 | 354.96 | 7.91 |
| Models | Methods | Coverage Rate | Number of Viewpoints | Path Length (mm) | Time (s) |
|---|---|---|---|---|---|
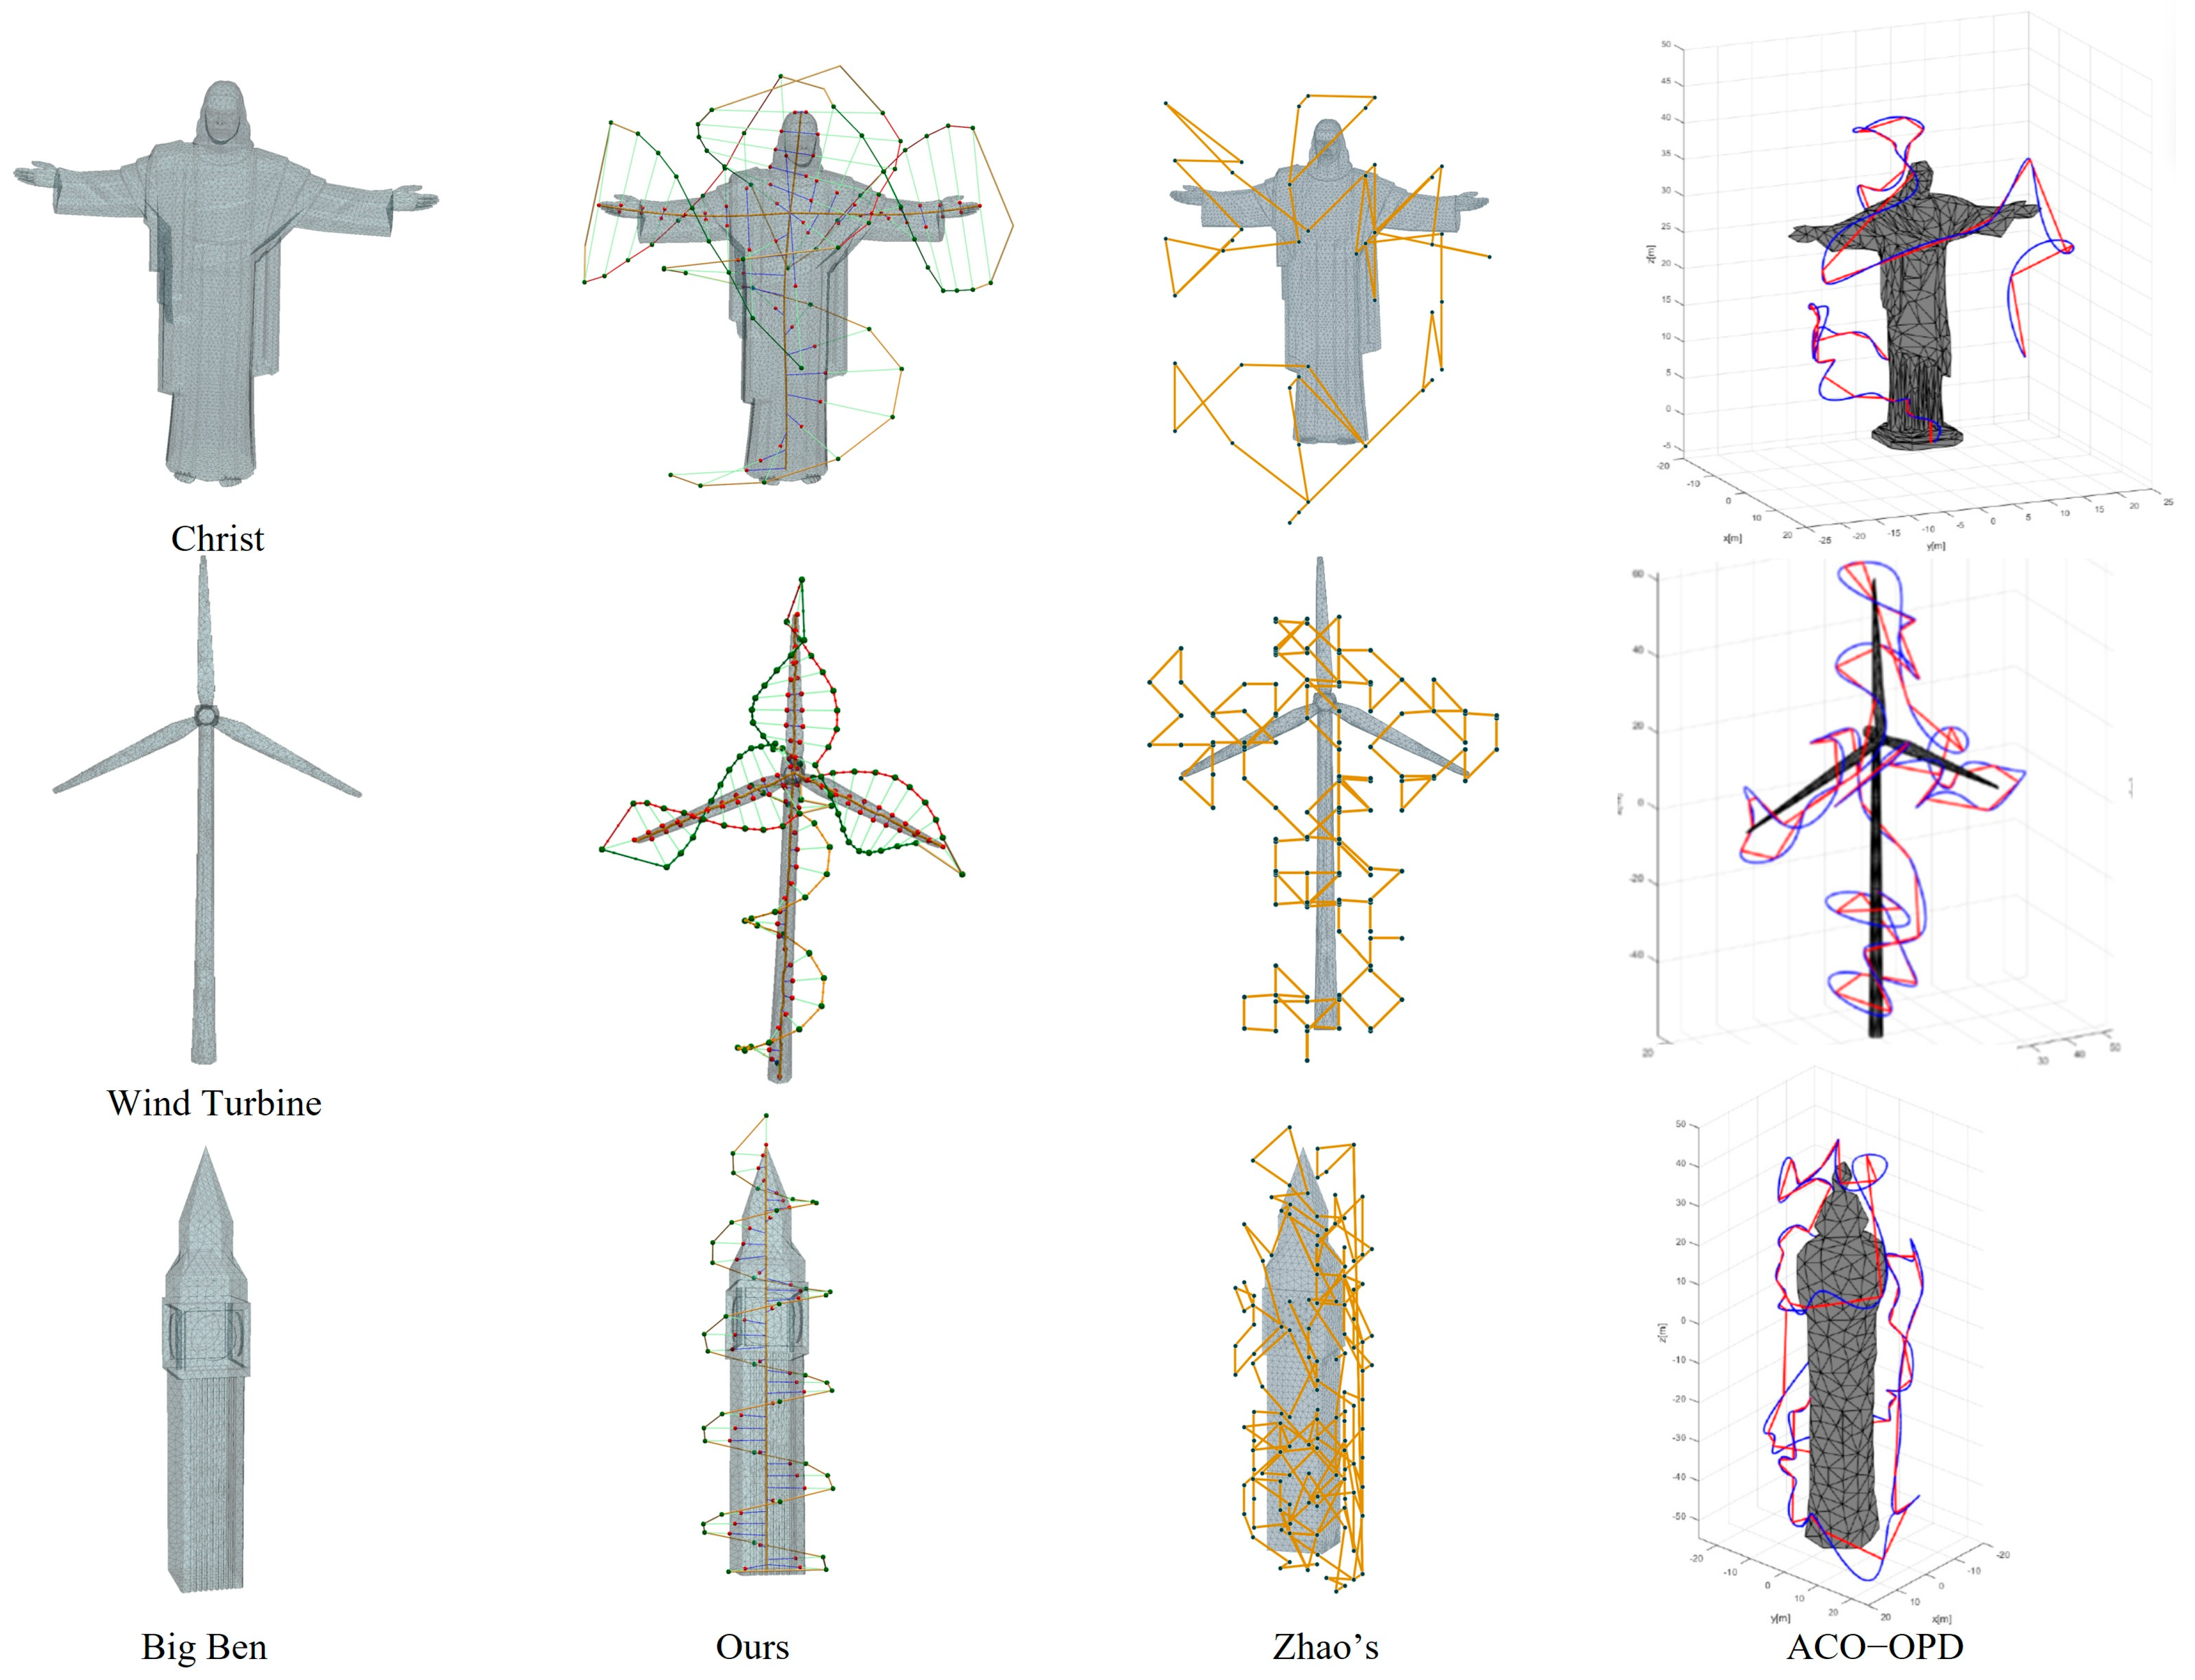
| Christ | Ours | 96.62% | 78 | 334.32 | 8.73 |
| ACO−OPD a | 100.00% | 80 | 337.63 | 322.36 | |
| Zhao’s algorithm b | 95.20% | 54 | 536.72 | 250.43 | |
| Wind Turbine | Ours | 97.72% | 102 | 560.81 | 13.64 |
| ACO−OPD a | 100.00% | 45 | 735.65 | 2570.97 | |
| Zhao’s algorithm b | 95.18% | 155 | 1607.84 | 490.47 | |
| Big Ben | Ours | 99.67% | 41 | 524.04 | 5.12 |
| ACO−OPD a | 100.00% | 70 | 630.84 | 311.75 | |
| Zhao’s algorithm b | 95.22% | 198 | 2414.70 | 688.30 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Zhang, Q.; Zhang, N.; Liu, Y.; Wang, Y. A Skeleton-Line-Based Spiral Coverage Path Planning Method for UAV Inspection of Three-Dimensional Structures. Appl. Sci. 2026, 16, 8743. https://doi.org/10.3390/app16178743
Zhang Q, Zhang N, Liu Y, Wang Y. A Skeleton-Line-Based Spiral Coverage Path Planning Method for UAV Inspection of Three-Dimensional Structures. Applied Sciences. 2026; 16(17):8743. https://doi.org/10.3390/app16178743
Chicago/Turabian StyleZhang, Qiang, Nan Zhang, Yue Liu, and Yunlong Wang. 2026. "A Skeleton-Line-Based Spiral Coverage Path Planning Method for UAV Inspection of Three-Dimensional Structures" Applied Sciences 16, no. 17: 8743. https://doi.org/10.3390/app16178743
APA StyleZhang, Q., Zhang, N., Liu, Y., & Wang, Y. (2026). A Skeleton-Line-Based Spiral Coverage Path Planning Method for UAV Inspection of Three-Dimensional Structures. Applied Sciences, 16(17), 8743. https://doi.org/10.3390/app16178743