1. Introduction
The development of exoskeletons for human mobility assistance and muscle strength augmentation has increased significantly in recent years. In this context, soft exoskeletons have been investigated as lightweight alternatives to traditional rigid devices, particularly in applications in which full structural reinforcement is not required. Unlike conventional exoskeletons, which rely on rigid frames capable of supporting high loads, soft exoskeletons employ compliant interfaces and flexible transmission mechanisms to deliver assistive forces while preserving natural joint kinematics [
1,
2]. Such wearable robotic systems are particularly well-suited for assisting individuals with reduced mobility, as even minimal and well-coordinated assistance has been shown to improve walking efficiency and reduce metabolic costs [
3,
4].
Beyond lower-limb exoskeletons, hierarchical and human-in-the-loop control architectures have also been explored in other human–machine interaction domains, such as safe reinforcement learning for quadcopter trajectory tracking from human demonstration [
5] and fixed-time adaptive learning for human–UAV collaborative control under state-input constraints [
6], underscoring the broader relevance of hierarchical control strategies in physically coupled human–machine systems.
Shortly thereafter, the XoSoft project [
7] proposed a modular configuration of soft actuators for the ankle, knee, and hip joints, enabling flexible and unilateral assistance using textile-integrated mechanisms. The clinical relevance of such systems has been further reinforced by randomized controlled trials demonstrating that robotic exoskeleton-assisted gait training yields significantly greater improvements in knee flexion torque, six-minute walk distance, and quality of life in post-stroke patients than conventional therapy alone [
8].
Subsequent research has emphasized the compactness, autonomy, and robustness of control. A lightweight 1.8 kg hip exosuit reduced the metabolic cost by 11.5% and muscle fatigue by 40.5% compared with unassisted walking [
9]. Iterative learning control strategies applied to Bowden cable-driven soft exoskeletons that provide coordinated hip and knee assistance have further demonstrated metabolic reductions in flat and uneven terrains, confirming the feasibility of single-actuator multi-joint architectures [
10]. This concept was extended by a self-contained, multi-joint soft exosuit that coordinated ankle plantar flexion and hip flexion-extension while traversing uneven terrain [
11]. From a control perspective, gait segmentation and force-based strategies were applied to a unilateral hip–knee exosuit, thereby enhancing joint mobility and posture in post-stroke patients [
12]. Meanwhile, an iterative proportional-derivative learning controller with feedforward compensation was developed for a hip-assistive exosuit, confirming its efficacy in reducing the metabolic effort during loaded walking [
13]. Lightweight cable-driven soft exosuits for hip flexion assistance have also extended the application domain beyond level walking; a portable waist-worn device reported a 6.9% average metabolic reduction and marked decreases in rectus femoris and lateral femoral muscle fatigue during stair climbing in older adults [
14]. A high-power hip–knee–ankle emulator was introduced to experimentally investigate coordination strategies for tendon-driven systems [
15], whereas a proportional-derivative iterative control strategy with gait prediction demonstrated accurate trajectory tracking and efficient hip–knee assistance in a simulation [
16].
In the structural control co-design of flexible multibody systems, the Lagrangian formulation is the most commonly used methodology for obtaining the equations of motion. Using the variational principles of geometric mechanics, the equations of motion in the Hamiltonian form can be derived for rigid body dynamics [
17]. The port-Hamiltonian (pH) framework [
18] has recently been employed to describe the dynamics of rigid and flexible links [
19,
20]. PH systems are intrinsically modular [
21]; hence, this approach naturally allows the construction of complex systems by interconnecting the atomic elements. The formulation naturally accounts for nonlinearities owing to the large deformations. However, this methodology relies on Lie algebra and differential geometry concepts and requires non-standard discretization techniques [
22].
Beyond exosuit-specific studies, model-based control of soft robotic systems more broadly illustrates the range of dynamic formulations available for tendon- and cable-driven mechanisms. To compensate for the nonlinear force losses inherent to Bowden-cable transmission, mechanical models of cable friction and elasticity have been combined with a dual-loop admittance–PID strategy to correct gait deviations at the knee and ankle [
23]. Lagrangian formulations remain the standard tool for deriving the equations of motion of soft robots, with applications including a direct formulation for soft robots [
24], an extension to a plant-inspired growing robot regulated through model-predictive control of task-space position, orientation, and interaction forces [
25], a combination with the piecewise-constant-curvature (PCC) method for continuum soft robots [
26], and a singularity-free formulation obtained via Taylor-series expansion for a two-segment continuum robot [
27]. As an alternative to the Lagrangian route, the extended Hamilton principle has been used to derive soft robot dynamics [
28]. Once a dynamic model is available, sliding-mode strategies are frequently used to reject the resulting uncertainties. For example, a super-twisting sliding-mode controller combined with an input estimator was used for end-effector position control [
29], and a super-twisting extended state observer enabled finite time attitude control [
30]. This class of robust control addresses model uncertainties, parameter variations, and external disturbances while guaranteeing finite-time convergence, making it particularly relevant for tasks that require high accuracy in the presence of strong environmental disturbances. Combining kinematic or dynamic models with data-driven control has also been shown to balance tracking accuracy and generalization, offering flexible performance for tasks requiring precision, robustness, and adaptive capabilities [
31].
Despite this progress, the control of soft exoskeletons remains insufficiently explored compared with their mechanical and ergonomic optimization. Many existing approaches rely on simplified dynamic representations or predominantly kinematic models that do not fully capture the nonlinear joint coupling or energy exchange introduced by tendon-driven transmissions [
15,
16]. The limitations of model-free strategies compared with model-based formulations have been characterized in the context of lower limb rehabilitation exoskeletons [
32], highlighting the advantages of incorporating explicit system dynamics to enable robust trajectory-tracking. Moreover, the inherent compliance of cable-driven actuation poses additional challenges in achieving robust closed-loop stability in the presence of model uncertainty and external disturbances. Only a limited number of studies have incorporated robust nonlinear controllers supported by formal stability proofs or provided physics-based closed-loop validation prior to experimental deployment [
33].
This highlights a clear opportunity to strengthen the control foundations of soft exoskeletons using model-based strategies with rigorous theoretical constraints. To address these gaps, this study presents the design, modelling, and control of a cable-driven soft exoskeleton for lower-limb rehabilitation assistance based on a nonlinear dynamic model formulated in the Hamiltonian framework. The coupled hip–knee dynamics are represented in an energy-based Hamiltonian framework, enabling the systematic characterization of nonlinear interactions and facilitating the control design. Building on this formulation, a hierarchical control architecture combining Quasi-Sliding Mode Control (QSMC) for angular regulation and Sliding Mode Control (SMC) for conjugate-momentum dynamics is developed to ensure robust trajectory tracking and disturbance rejection. A Lyapunov-based stability analysis formally establishes the asymptotic stability of the closed-loop system and derives explicit gain conditions for robust tracking in the presence of bounded disturbances. In addition, a compact winch-based actuation module was designed and geometrically optimized using a genetic algorithm to reduce the distal mass while preserving mechanical robustness and ergonomic wearability. The proposed framework was validated using a two-stage simulation approach: numerical analysis in MATLAB–Simulink® R2020b and physics-based testing in MuJoCo integrated with ROS2, where the contact dynamics, friction, and cable compliance were explicitly considered. A modular mechanical prototype was developed and evaluated by users with different anthropometric profiles to assess its fit and structural feasibility. The main contributions of this study are as follows.
Development of a nonlinear dynamic model of the bilateral hip–knee system using a Hamiltonian formulation that explicitly captures energy storage, transfer, and nonlinear coupling under tendon-driven actuation.
Design of a hierarchical QSMC-SMC control architecture for robust trajectory tracking, with a formal Lyapunov-based stability analysis that establishes asymptotic stability and provides explicit gain conditions for disturbance rejection.
Geometric optimization of a cable-driven actuation module using a genetic algorithm to minimize the distal mass while satisfying mechanical and wearability constraints.
Two-stage simulation validation was performed by combining analytical evaluation in MATLAB–Simulink® and physics-based testing in the MuJoCo–ROS2 environment, where cable compliance, friction, and contact dynamics were explicitly modeled.
A modular mechanical prototype was constructed, and its fit across users with different anthropometric characteristics was qualitatively assessed, supporting the structural feasibility of the cable-driven actuation concept before the integration of electronic subsystems.
The remainder of this paper is organized as follows.
Section 2 describes the mechanical design, actuation module optimization, dynamic modelling, control formulation, and stability analysis.
Section 3 presents the simulation results and prototype validation of the proposed model.
Section 4 discusses the implications and limitations of the proposed method.
Section 5 presents the conclusions and directions for future research.
2. Materials and Methods
2.1. Exoskeleton Design
The proposed soft exoskeleton is designed to assist with hip and knee flexion-extension in the sagittal plane, targeting elderly users (55–70 years old) with reduced mobility who can still maintain an upright posture and do not have severe joint pathologies. This type of assistance is particularly relevant for age-related declines in mobility or recovery from non-neurological musculoskeletal conditions, where moderate and well-coordinated support can significantly improve gait efficiency.
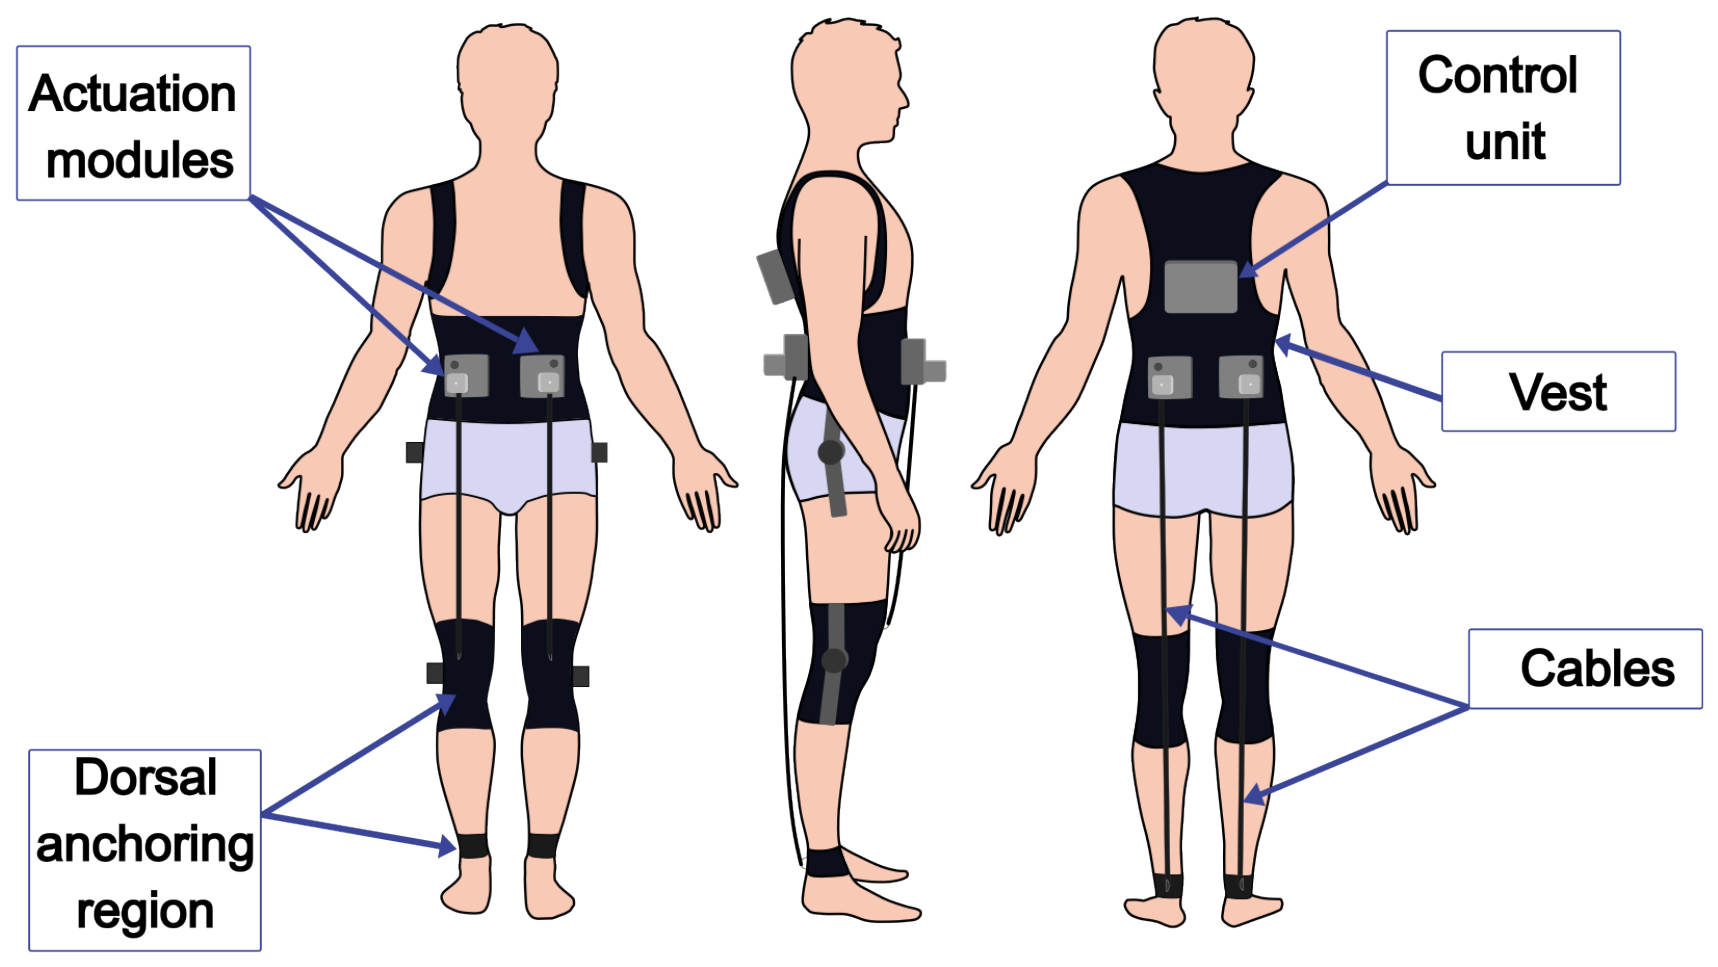
The mechanical architecture is based on an orthopaedic vest that anchors the actuation modules both frontally and dorsally, ensuring a balanced force distribution across the torso and reducing long-term discomfort. The control and actuation units were located in the central dorsal region of the vest to minimize distal inertia, as illustrated in
Figure 1. This configuration reduces the load on the lower limbs and facilitates natural walking.
This age-related target population was further refined using regional anthropometric criteria, as reduced mobility was more prevalent in the study region among individuals within specific height and body mass ranges. Accordingly, the design targets users from southeastern Mexico, where the average anthropometric characteristics are below the national mean [
34,
35]. Specifically, the system is intended for individuals between 1.45 and 1.70 m in height and 50–70 kg in body mass, without gender distinction.
According to the anthropometric proportions reported in [
36], the hip–knee segment corresponds to approximately 24.5% of the body height and 10% of the total body mass, whereas the knee–ankle segment accounts for 28.5% of the height and 5% of the body mass. These ratios were used to define the maximum Bowden cable length and ensure adaptability across the users. The vest and textile interfaces are adjustable, allowing secure anchoring and alignment with individual body morphologies.
2.2. Actuation Module and Optimised Cable-Driven Transmission
Assistive actuation is provided through a waist-mounted winch mechanism that winds and releases Bowden cables to generate tensile forces that are transmitted to the lower limbs.
By locating the actuation units on the torso rather than directly on the limbs, the proposed architecture significantly reduces the distal mass and inertia, facilitating more natural gait dynamics and enhancing the overall user comfort. Bowden cables withstand the tensile loads required for assistance while preserving flexibility, thereby emulating the behavior of biological tendons in the human body.
The actuation module is inspired by a safety anchoring mechanism [
37]; however, it constitutes a substantially modified design rather than a direct modification. Several structural modifications have been introduced to adapt the robotic assistance mechanism to a portable format. In particular, the original manual crank input was replaced with a DC motor, enabling precise torque control and compatibility with closed-loop control systems. Additionally, the overall geometry of the transmission was reconfigured to facilitate subsequent geometric optimization and allow ergonomic integration at the user’s waist without restricting trunk motion.
To systematically reduce the geometric size of the transmission while preserving its mechanical integrity and efficiency, a genetic algorithm (GA) was employed as a design support tool to optimize the gear train parameters. Unlike conventional optimization approaches that directly minimize mass, the GA was formulated to promote geometric compactness and efficient load transmission because the final weight strongly depends on the material selection, which is addressed in a later design stage.
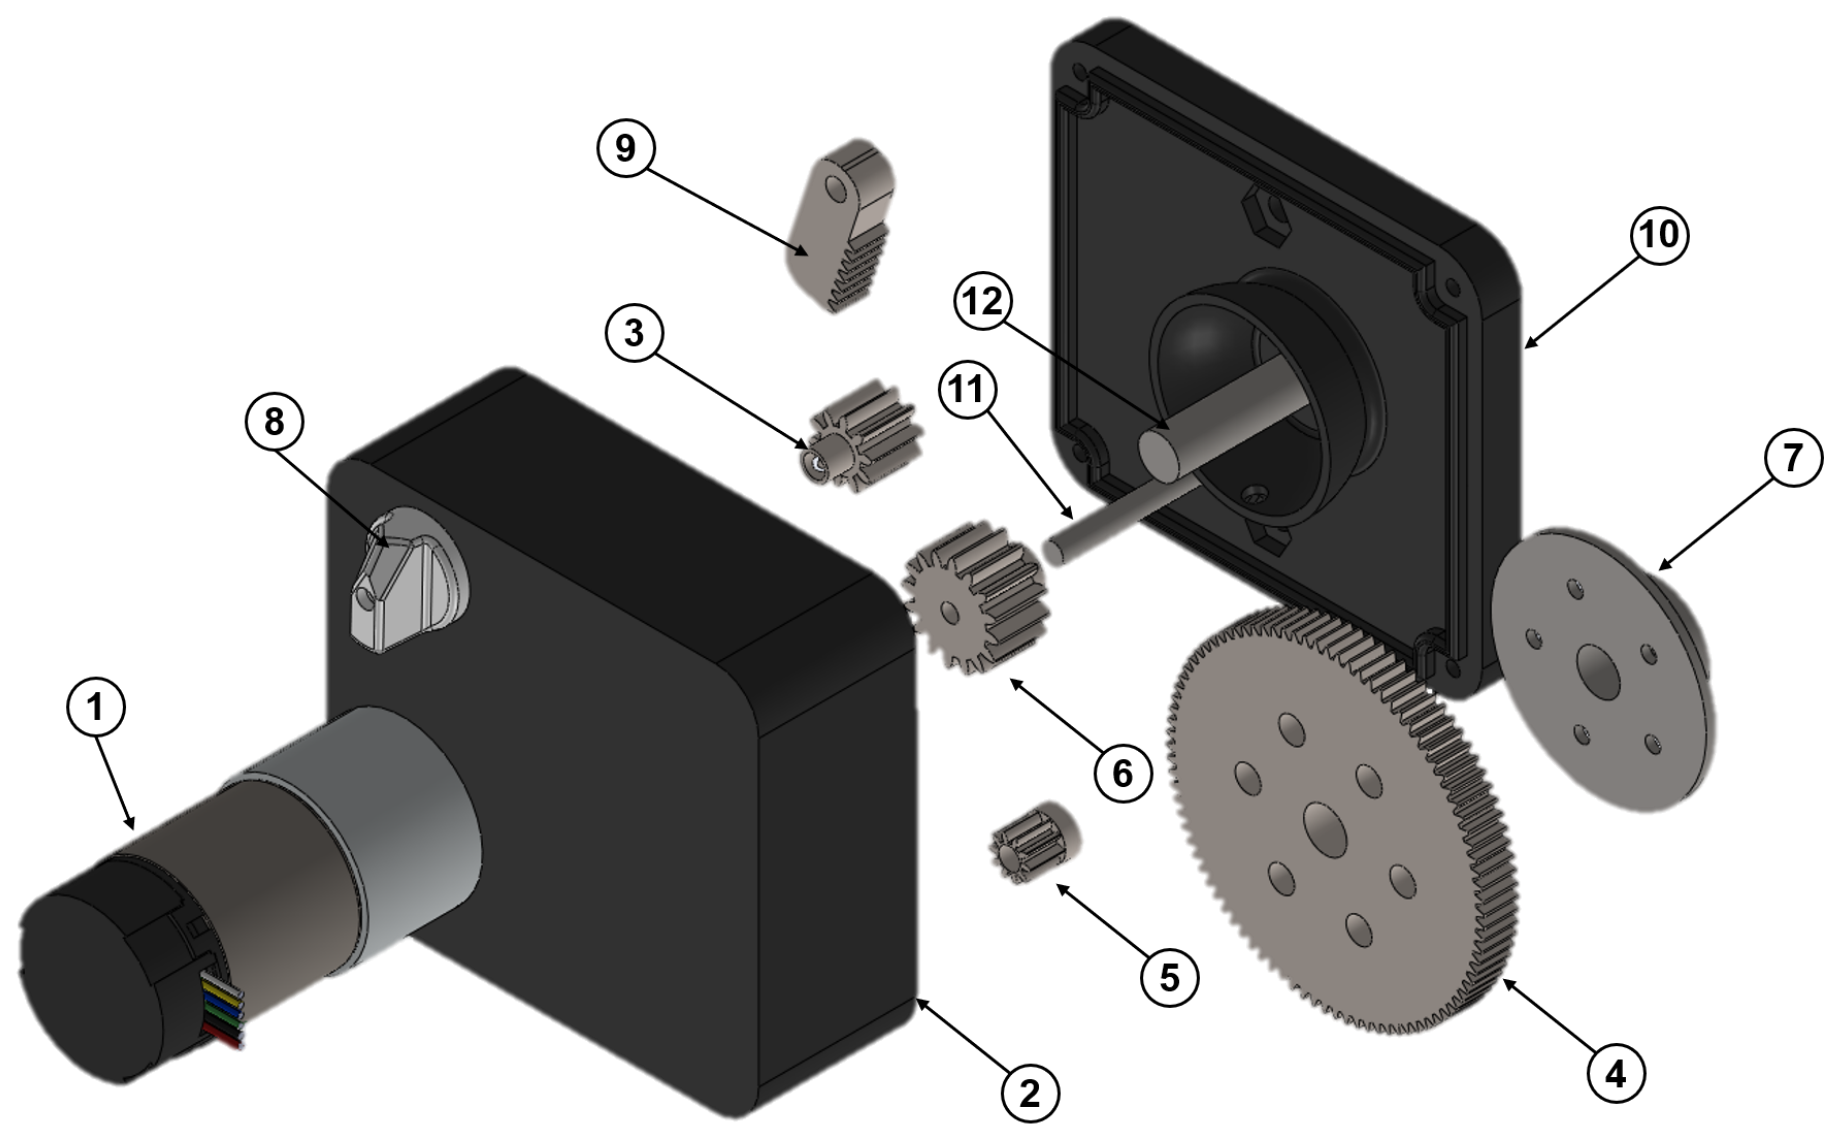
The optimization problem focused on the gear train comprising gears 3–6. The design variables included gear modules (, ), face widths (, ), and the number of teeth (, , ), whereas was determined using the required transmission ratio. The mechanical constraints included admissible bending and contact stresses for each gear pair, torque limits imposed by the DC gearmotor, efficiency requirements for both gear stages, and a maximum cable tension corresponding to an assistive load of 15 kg.
The GA was implemented with a population of 150 individuals, evolving over 100 generations with a maximum stagnation of 80 generations. Tournament selection was used in conjunction with a simulated binary crossover (probability 0.8) and integer mutation to preserve the feasibility of discrete gear parameters within a MATLAB® implementation. The resulting optimized configuration significantly reduced the radial dimensions and axial length of the mechanism, allowing its integration into a portable module mounted on the waist of the user.
Figure 2 shows the optimized winch CAD model. The detailed nomenclature of the transmission components is presented in
Table 1, and the optimized gear-train parameters are summarized in
Table 2.
The selected DC gearmotor (Pololu 37D metal gearmotor, Pololu Robotics and Electronics, Las Vegas, NV, USA, 10:1 ratio, 12 V) provided an extrapolated stall torque of 0.4805 N·m (4.9 kgf·cm) at a stall current of 5.5 A, with a no-load speed of 1000 RPM. Combined with the optimized gear-train ratio of 14.4:1 (
Table 2) and accounting for an estimated two-stage transmission efficiency of 80%, the maximum torque delivered to the 12.5 mm-radius cable drum was approximately 5.53 N·m, corresponding to a maximum cable tension of ≈443 N.
The overall mass of the exoskeleton was evaluated after mechanical redesign and selection of lightweight structural materials using CAD-derived mass properties, manufacturer specifications for commercial components, and direct measurements of the textile elements.
Table 3 presents the mass distributions of the complete system. The resulting total mass of 3.68 kg reflects the combined effects of relocating the actuation units to the torso, minimizing the distal inertia, and optimizing the transmission geometry. This system-level mass distribution is explicitly incorporated into the dynamic model formulation to ensure consistency between the mechanical design and the control-oriented analysis.
2.3. Dynamic Model
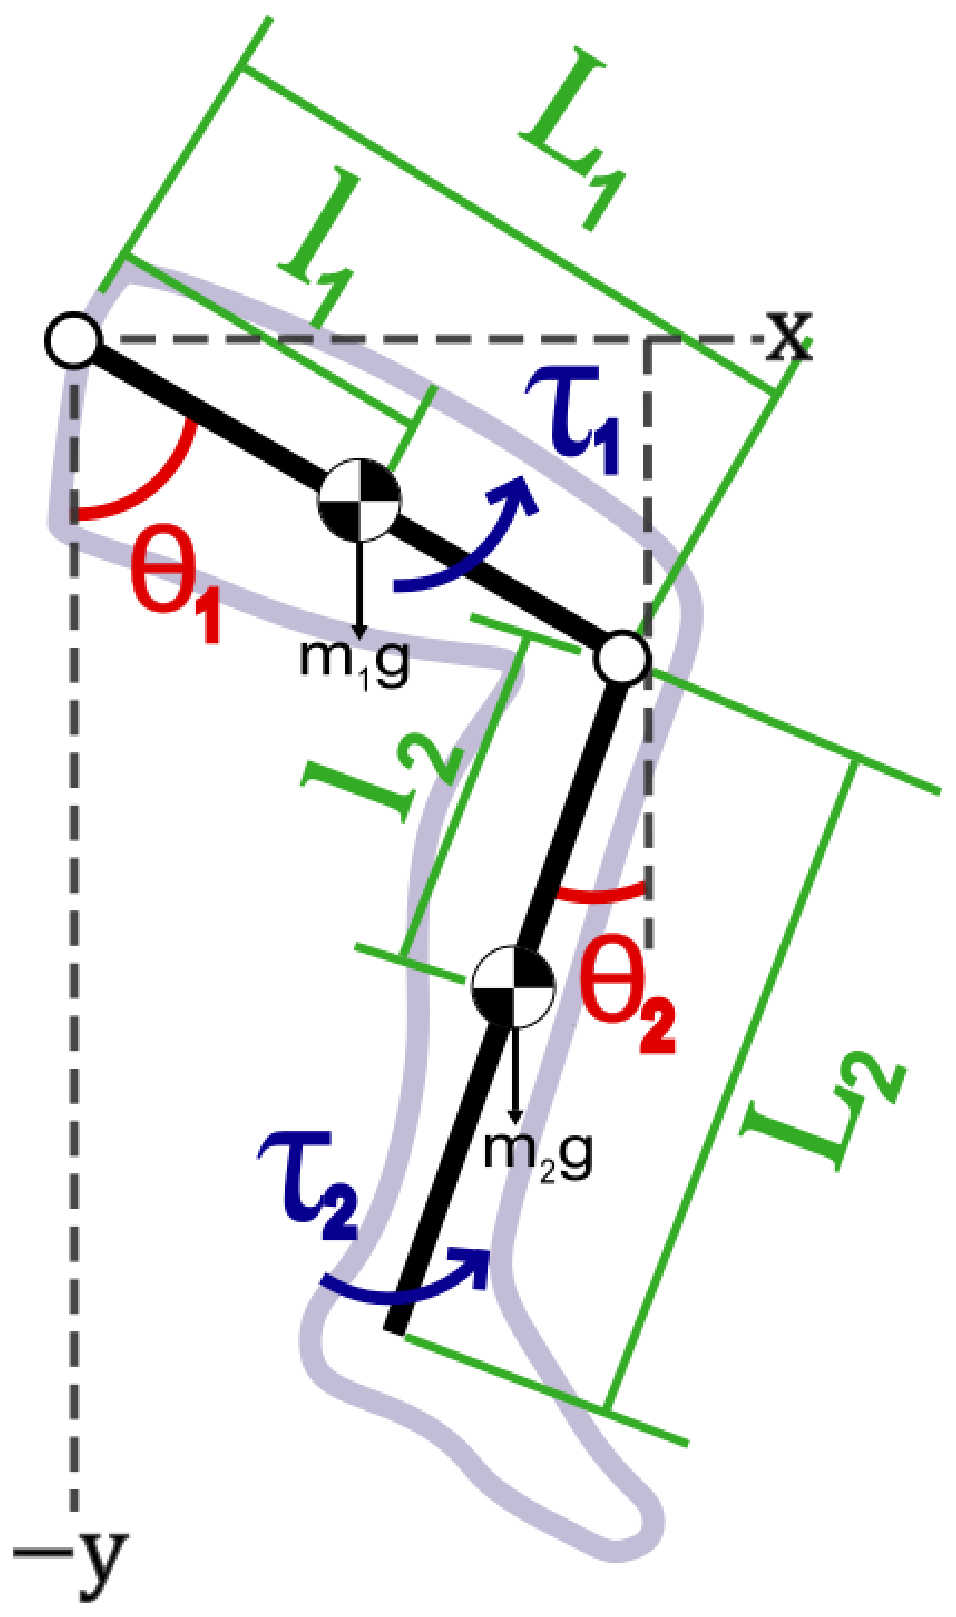
Because the lower limbs can be approximated as rigid segments connected by joints, their motion involves posture-dependent and nonlinear interactions. Therefore, accurate dynamic modelling is essential for reproducing human gait with sufficient fidelity. The lower limbs were modelled as fully actuated double pendulums in the sagittal plane, capturing the dominant dynamics of the hip and knee joints, for which the governing nonlinear equations of motion were derived.
Each limb segment is modelled as a uniform slender rod of length
, with its own mass
uniformly distributed, and its center of mass located at
. For the coupling terms, the mass of the distal segment was treated as concentrated at its own center of mass, which yielded full inertial coupling between segments while correctly capturing the gravitational torque contribution at each joint. The generalized coordinate
denotes the joint angle of segment
i, measured from the vertical (downward) direction, and
is the moment of inertia of segment
i about its center of mass, obtained from the standard slender-rod expression
evaluated at
. The corresponding moment of inertia about the proximal joint is subsequently obtained via the parallel-axis term
, which appears explicitly in Equations (
1) and (
2), where
denotes the actuation torque applied at joint
i.
Using the Euler–Lagrange formulation applied to the free-body diagram shown in
Figure 3, the equations of motion are obtained as
Although the equations of motion were initially derived using the Euler–Lagrange formulation, this representation was not directly adopted for the control design. Although the Lagrangian approach is convenient for modelling articulated mechanical systems, it does not explicitly expose the energetic structure of the dynamics when expressed in the state-space form. Therefore, for the control-oriented analysis, the system was reformulated using the Hamiltonian framework. This formulation introduces the conjugate momenta as state variables and yields a first-order representation that explicitly captures the energy storage, transfer, and coupling effects, which are particularly relevant for cable-driven soft exoskeletons, where compliant actuation and tendon dynamics are central to system behavior.
Accordingly, Equations (
3)–(
5) define the conjugate momentum of the system in matrix form,
Solving this system yields the time derivatives of the angular positions,
where
Using the Legendre transformation, the Hamiltonian function is defined as
Applying Hamilton’s canonical equations, the time derivatives of the conjugate momenta are obtained as
From a physical perspective, the Hamiltonian function represents the total mechanical energy of the lower-limb system, which is composed of the kinetic energy expressed in terms of the conjugate momenta and gravitational potential energy associated with the limb segments. This energy-based representation provides direct insight into how control actions inject, redistribute, or dissipate energy within the coupled hip–knee system, which is particularly valuable in wearable robotics, where safe and effective assistance is closely linked to the controlled exchange of energy between the exoskeleton and human user.
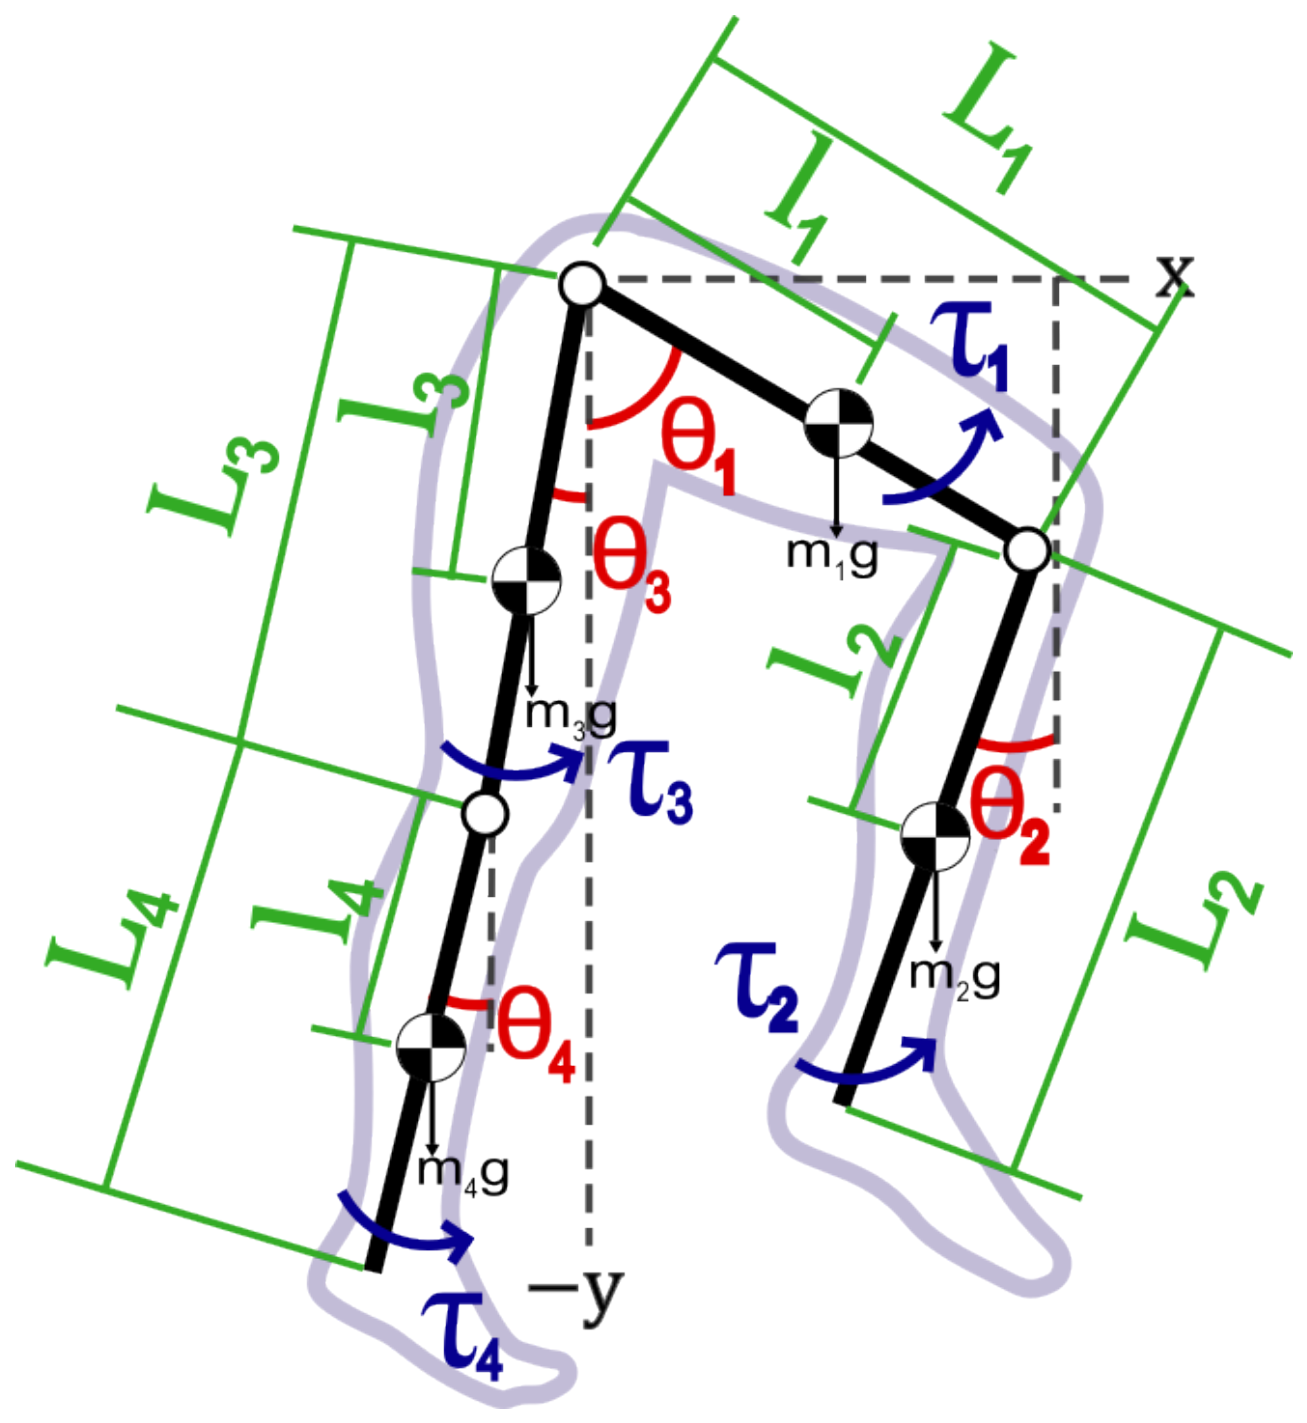
To represent the complete locomotor system, the dynamic model was extended to include both the lower limbs, as shown in
Figure 4. Each leg was modelled as a fully actuated double pendulum, whereas the pelvis was assumed to behave as a rigid body, providing a common reference frame for both limbs. This choice enabled the representation of the alternating swing and stance dynamics during gait without explicitly introducing ground contact constraints. Although restricted to sagittal-plane motion, the formulation provides a sufficiently accurate approximation for analyzing hip and knee flexion–extension assistance while preserving analytical tractability.
The contralateral limb follows the same Euler–Lagrange, Legendre-transform, and Hamiltonian procedures used to obtain Equations (
1)–(
8), with indices
replaced by
. Equations (
9)–(
16) summarize the resulting bilateral state-space dynamics.
where
To represent the alternating nature of the gait, a phase shift was introduced between the two double pendulum systems. The left leg is described by
and
, whereas the right leg is initialized with phase-shifted initial conditions for
and
where
and
denote the prescribed phase differences between the left and right limbs.
Therefore, the reference trajectories and torque levels employed in this study were selected to remain within physiologically realistic ranges, ensuring biomechanical safety while assisting the user. These considerations also guided the design of the nonlinear control strategy, which must operate within safe limits while compensating for tendon compliance, Bowden cable friction, and interaction forces during the gait.
2.4. Control Design
The control strategy proposed in this study was directly motivated by the Hamiltonian structure of the system. The Hamiltonian formulation naturally separates the dynamics into angular variables and conjugate momenta, each of which is associated with a distinct physical role in the system. Angular coordinates primarily govern kinematic coordination and gait tracking, whereas momentum variables capture inertial effects, energy transfer, and sensitivity to external disturbances. Consequently, the control architecture was organized hierarchically and in a cascaded manner, with complementary control objectives assigned to each variable set.
By independently regulating the angular and momentum variables, the controller addressed distinct dynamic phenomena at the appropriate levels. Direct angular control enforces coordination and trajectory tracking, whereas momentum regulation provides robustness against modelling uncertainties, unmodelled dynamics and external perturbations. This approach avoids relying solely on high-gain torque feedback to compensate for dynamic coupling, which is particularly important in tendon-driven soft exoskeletons, where high-frequency switching can amplify cable compliance and excite unmodelled dynamics.
2.4.1. Sliding Surfaces
Let
denote the vector of measured joint angles and
the desired trajectories. The joint-space tracking error and its time derivative are defined as
The sliding surface associated with angular position tracking is
where
is a positive-definite diagonal matrix governing the convergence rate of the angular error.
For the conjugate momentum dynamics, the tracking error and sliding surface are
2.4.2. Quasi-Sliding Mode Control for Angular Positions
At the angular level, chattering is mitigated by replacing the ideal discontinuous sign function with a continuous saturation function, introducing a quasi-sliding boundary layer while preserving robustness against bounded disturbances. The outer-loop QSMC generates the desired auxiliary joint velocity
where
ensures robustness to parameter variations and external disturbances, and
defines the quasi-sliding boundary layer. The saturation function is implemented component-wise as
2.4.3. Computation of Desired Conjugate Momentum
Once the desired angular velocity is obtained, the corresponding desired conjugate momenta are computed from a control-oriented representation of the dynamics as follows
where
is the inertia matrix,
accounts for the Coriolis and centrifugal effects, and
represents gravitational torques.
2.4.4. Sliding Mode Control for Conjugate Momentum
The inner loop employs a classical SMC law to ensure the asymptotic convergence of the conjugate momenta to their desired values
. The joint torque command is as follows
where
controls the linear convergence of
, and
compensates for the matched uncertainties and the unmodelled dynamics.
2.5. Stability Analysis
The closed-loop stability of the system was analyzed using Lyapunov’s theory. The proposed architecture is cascaded and comprises an inner momentum control loop and an outer angular-position loop. Stability is first established for each subsystem and then for the interconnection. For this analysis, ideal sliding-mode control laws employing a discontinuous sign function were considered, and a practical saturation-based implementation was presented.
2.5.1. Inner-Loop Stability (Momentum Dynamics)
The momentum sliding surface is
. Under the ideal control law (
23), the closed-loop dynamics are
where
denotes a bounded disturbance. Consider the Lyapunov candidate
. Its time derivative satisfies
where
is a known upper bound on the
i-th disturbance component. Hence
is negative definite provided that
guaranteeing asymptotic convergence
.
2.5.2. Outer-Loop Stability (Angular Dynamics)
The angular sliding surface is
. Assuming the inner-loop dynamics are sufficiently fast so that
, the reduced sliding-surface dynamics are
where
represents bounded uncertainties with
. For the Lyapunov function
,
which is negative definite, provided that
2.5.3. Cascaded Stability and Practical Implementation
By selecting gains such that the inner-loop dynamics are significantly faster than the outer-loop dynamics, the time-scale separation condition required for cascaded stability is satisfied, and the ideal closed-loop system is asymptotically stable in the Lyapunov sense. In practical implementations, the discontinuous sign function is replaced by a saturation function to mitigate chattering, introducing a boundary layer within which the system trajectories remain bounded uniformly. The bounded oscillations observed in the control torques during the simulation were consistent with the quasi-sliding behavior.
2.6. Simulation Frameworks
A two-stage simulation framework was implemented to verify the performance and robustness of the proposed control strategies. The first stage consisted of an analytical validation in MATLAB–Simulink®, where the complete nonlinear dynamics of the lower-limb double pendulum were modelled and controlled using the proposed QSMC-SMC. The second stage involved physics-based validation using MuJoCo integrated with ROS2, which provided a realistic environment for assessing the controller behavior under gravity, contact interactions, and cable compliance.
2.6.1. Analytical Validation in MATLAB–Simulink®
The MATLAB–Simulink
® stage focused on validating the proposed control laws under idealized, noise-free conditions. The full double-pendulum equations were integrated with the QSMC and SMC loops to evaluate the closed-loop stability and tracking performance.
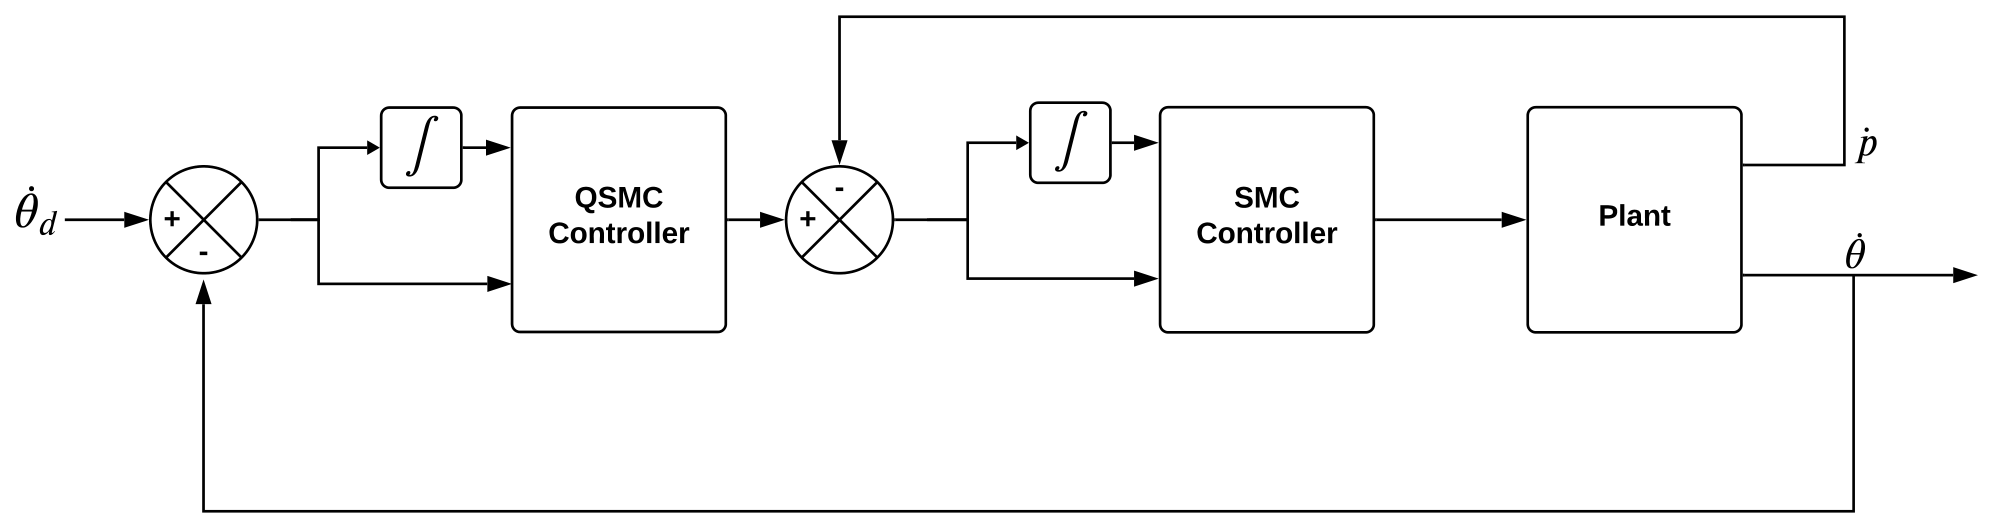
Figure 5 illustrates the modular control architecture: (i) the
Desired Trajectory block generates periodic hip and knee reference profiles within physiological limits; (ii) the
QSMC module computes the desired conjugate momenta from angular tracking errors; (iii) the
SMC block generates actuator torques to ensure momentum convergence; and (iv) the
Dynamic Model block reproduces the nonlinear double-pendulum behavior of the lower limbs. The feedback of
,
,
p, and
closes this loop.
All simulations were conducted for 10 s with a fixed integration step of 1 ms and a fourth-order Runge–Kutta scheme. The controller gains were tuned to achieve fast transients while limiting the control effort and suppressing the high-frequency oscillations.
2.6.2. Physics-Based Validation in MuJoCo–ROS2
The physics-based stage was performed using MuJoCo [
38] integrated with the ROS2 framework [
39], providing a physics-consistent environment for assessing real-time interaction between control algorithm and mechanical system under the combined effects of gravity, friction and contact.
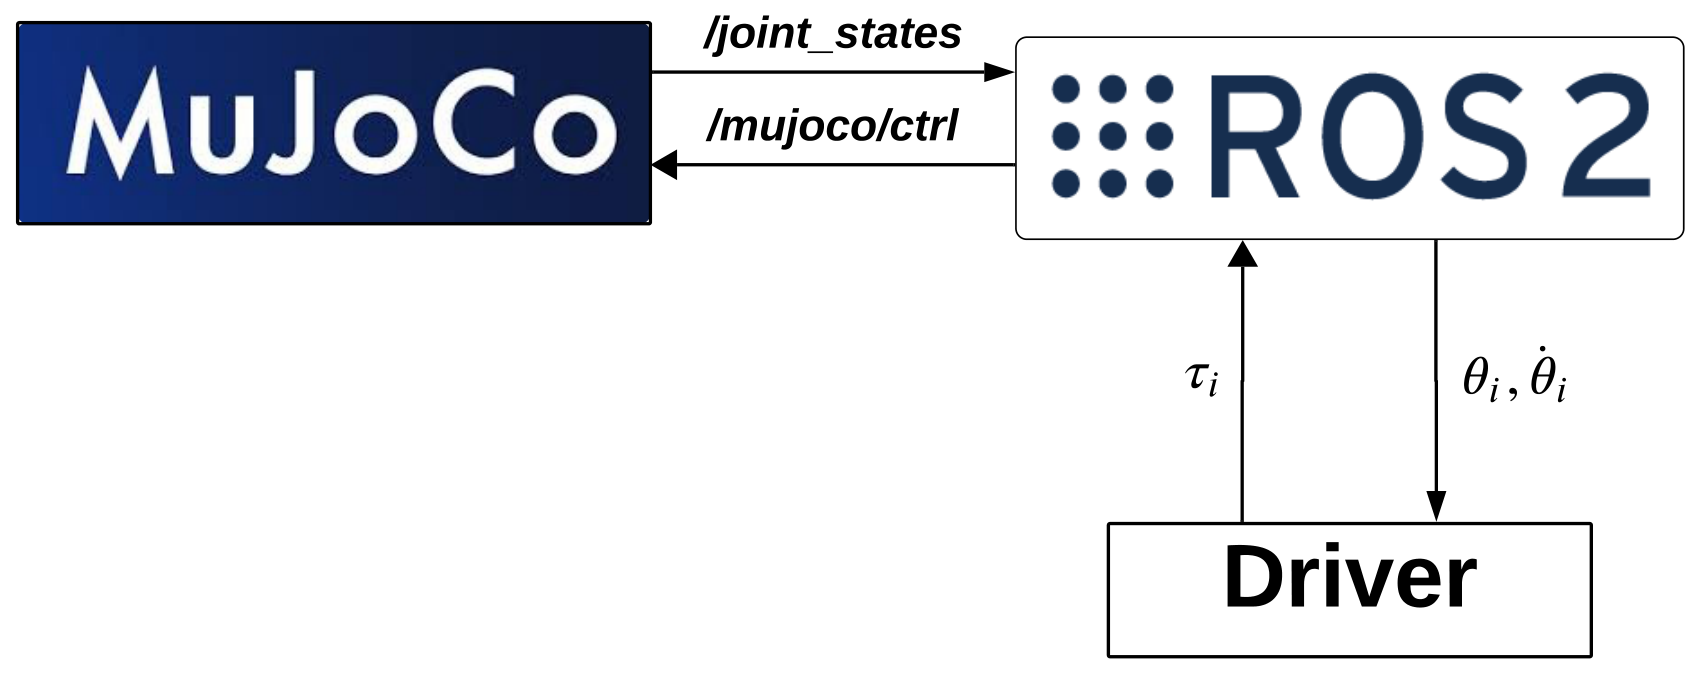
Because MuJoCo does not natively support custom control laws based on explicit dynamic equations, ROS2 integration was employed to programmatically implement the proposed control strategy. Joint states are transmitted from MuJoCo to ROS2 via the
/joint_states topic, whereas the computed control torques are returned via the
/mujoco/ctrl topic to enable continuous closed-loop operation.
Figure 6 illustrates this communication architecture.
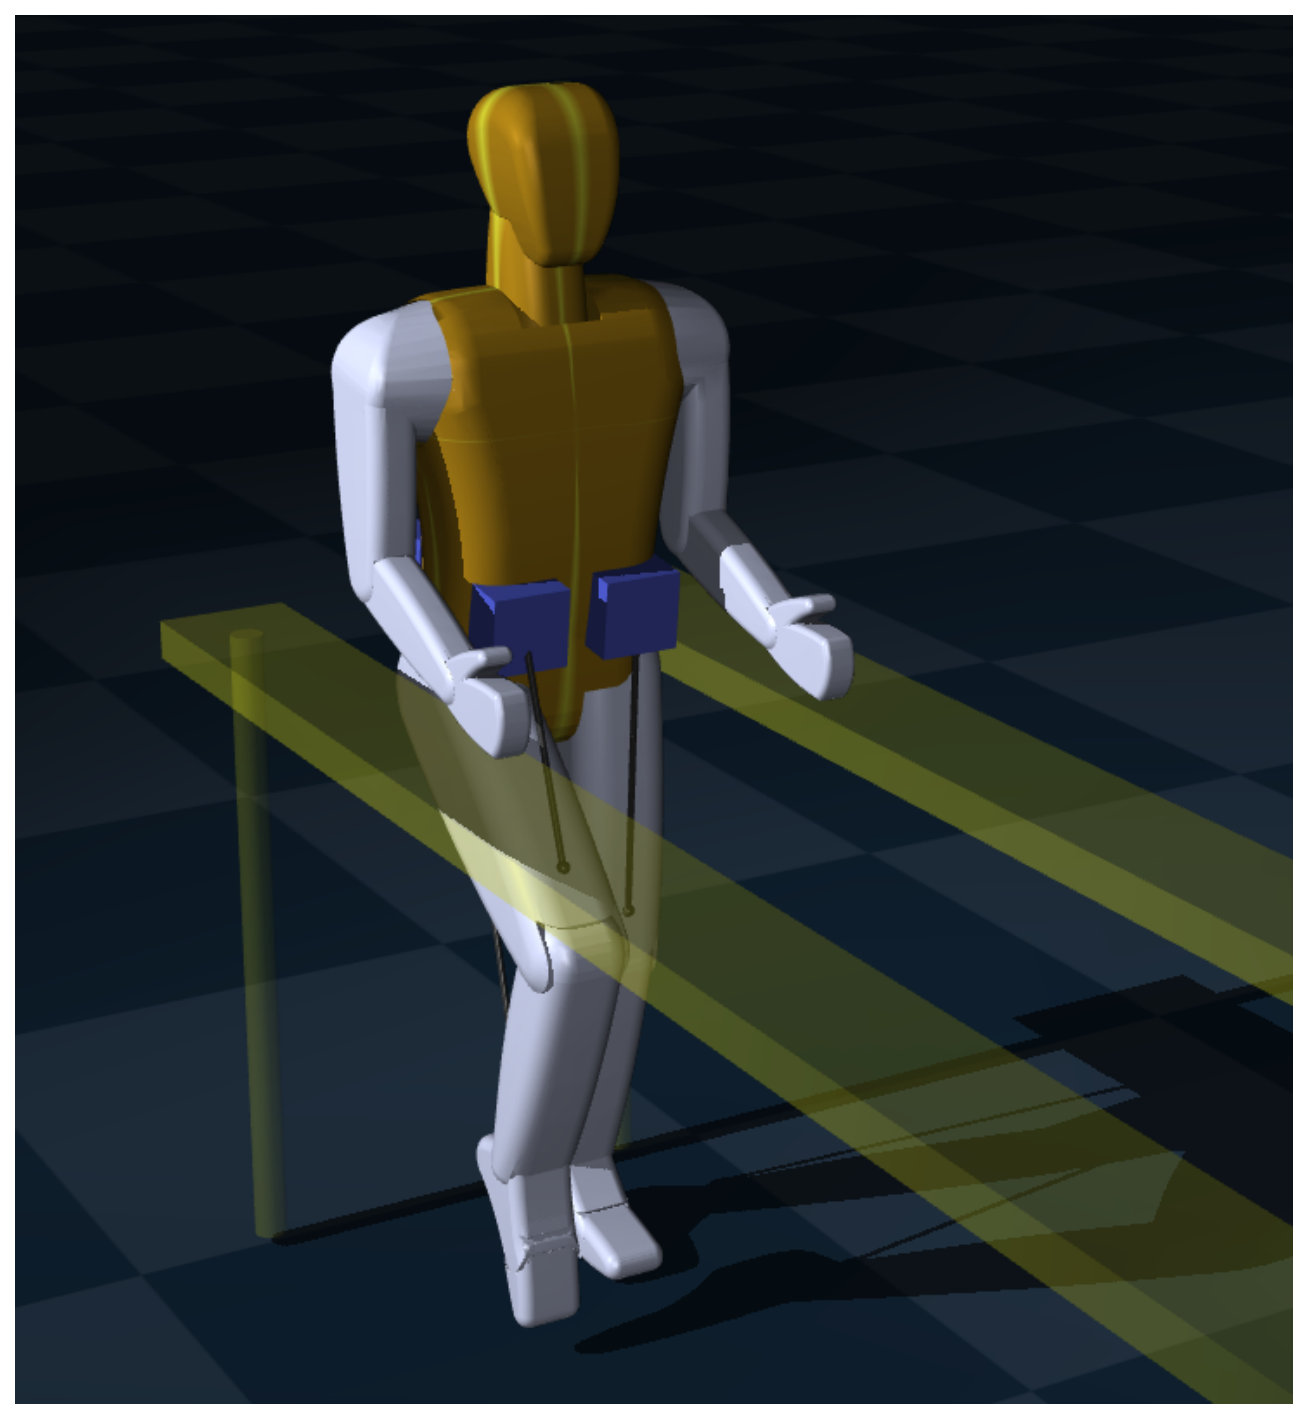
The anthropomorphic model, shown in
Figure 7, consists of articulated rigid-body segments representing the torso, upper limbs, thighs, shanks, ankles, and feet with realistic mass distributions and joint limits. Passive toe contacts were included to improve stance stability under gravity, whereas Bowden-type tendons actuated the hip and knee joints to reproduce flexion–extension cycles. All components were defined using URDF descriptions that specified link properties, joint constraints, and tendon routing. A fixed handrail was incorporated to emulate the postural support commonly used in rehabilitation environments and to ensure static balance during validation.
The quantitative evaluation presented in this study is intentionally restricted to MATLAB–Simulink® simulations, which characterize the interaction between the hierarchical controller and the Hamiltonian-based model under controlled conditions. The MuJoCo–ROS2 environment served as a qualitative intermediate validation step, confirming that the control architecture operated without numerical divergence under realistic physical constraints. A more extensive quantitative analysis within this framework is reserved for future studies focused on experimental and physics-based validation.
Together, these simulation frameworks establish a consistent environment for assessing the proposed control strategy prior to its experimental implementation.
3. Results
The performance of the proposed model-based nonlinear control strategy was evaluated using numerical simulations. The results reported in this section are intended to illustrate the closed-loop behavior predicted by the theoretical analysis rather than provide an exhaustive performance benchmarking. Analytical simulations conducted in MATLAB–Simulink® characterized the interaction between the hierarchical QSMC-SMC controller and the Hamiltonian-based double-pendulum model under controlled, noise-free conditions. Physics-based simulations conducted in the MuJoCo–ROS2 environment were used to qualitatively assess the feasibility of the proposed control architecture under realistic conditions, including contact dynamics, friction, and cable compliance. To maintain a clear focus on the analytical modelling and stability properties of the control strategy, the quantitative evaluation presented in this study was intentionally restricted to MATLAB–Simulink® simulations. A more extensive quantitative analysis within the MuJoCo–ROS2 framework is reserved for future work, focusing on experimental and physics-based validation.
In both stages, the joint positions of the hip and knee (first and second pendulums, respectively) were presented during periodic profiles that were representative of the human gait in the sagittal plane.
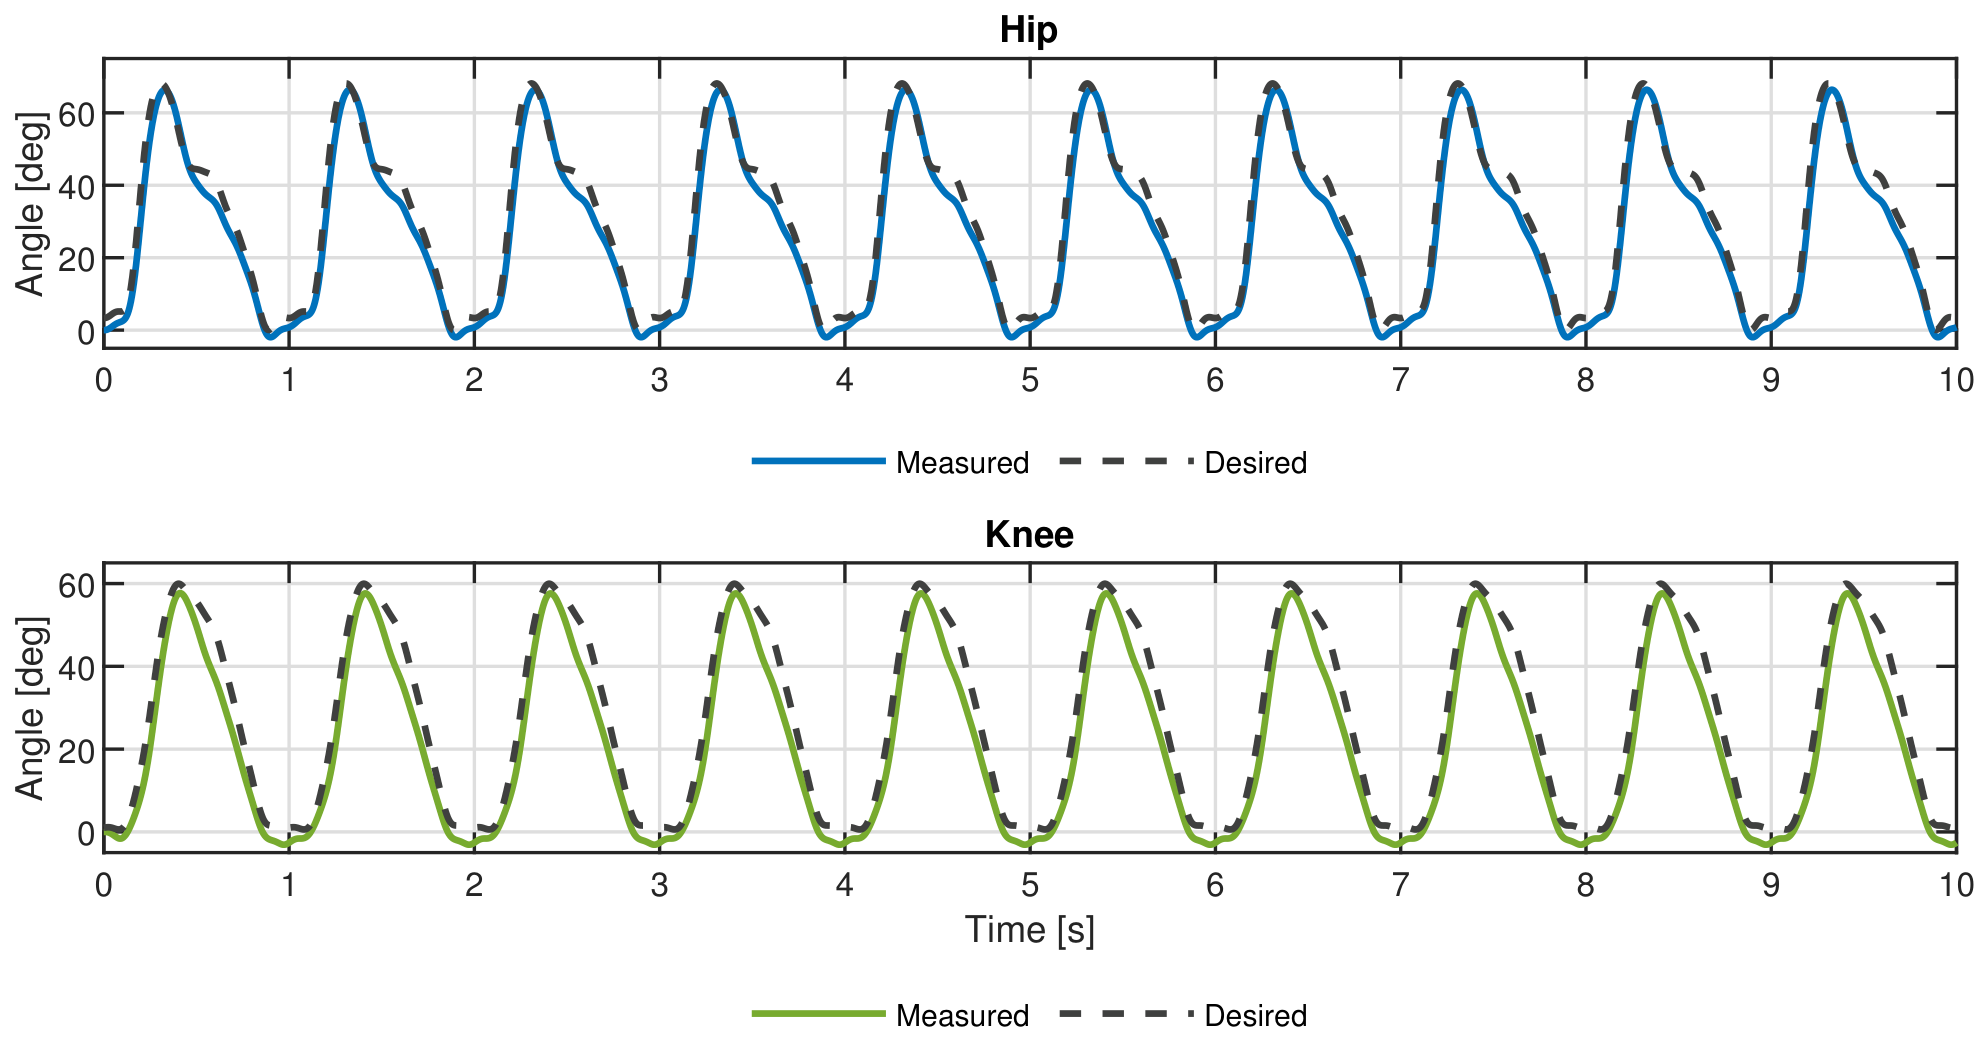
Figure 8 shows the desired and measured hip and knee joint angles during periodic motion corresponding to a ten-step gait cycle. The measured trajectories closely followed the reference profiles throughout the simulated gait cycle. The hip joint exhibited periodic motion ranging from approximately
to
, whereas the knee joint ranged from approximately
to
. The absence of a large initial transient and regular waveform indicates a stable tracking behavior consistent with the theoretical analysis.
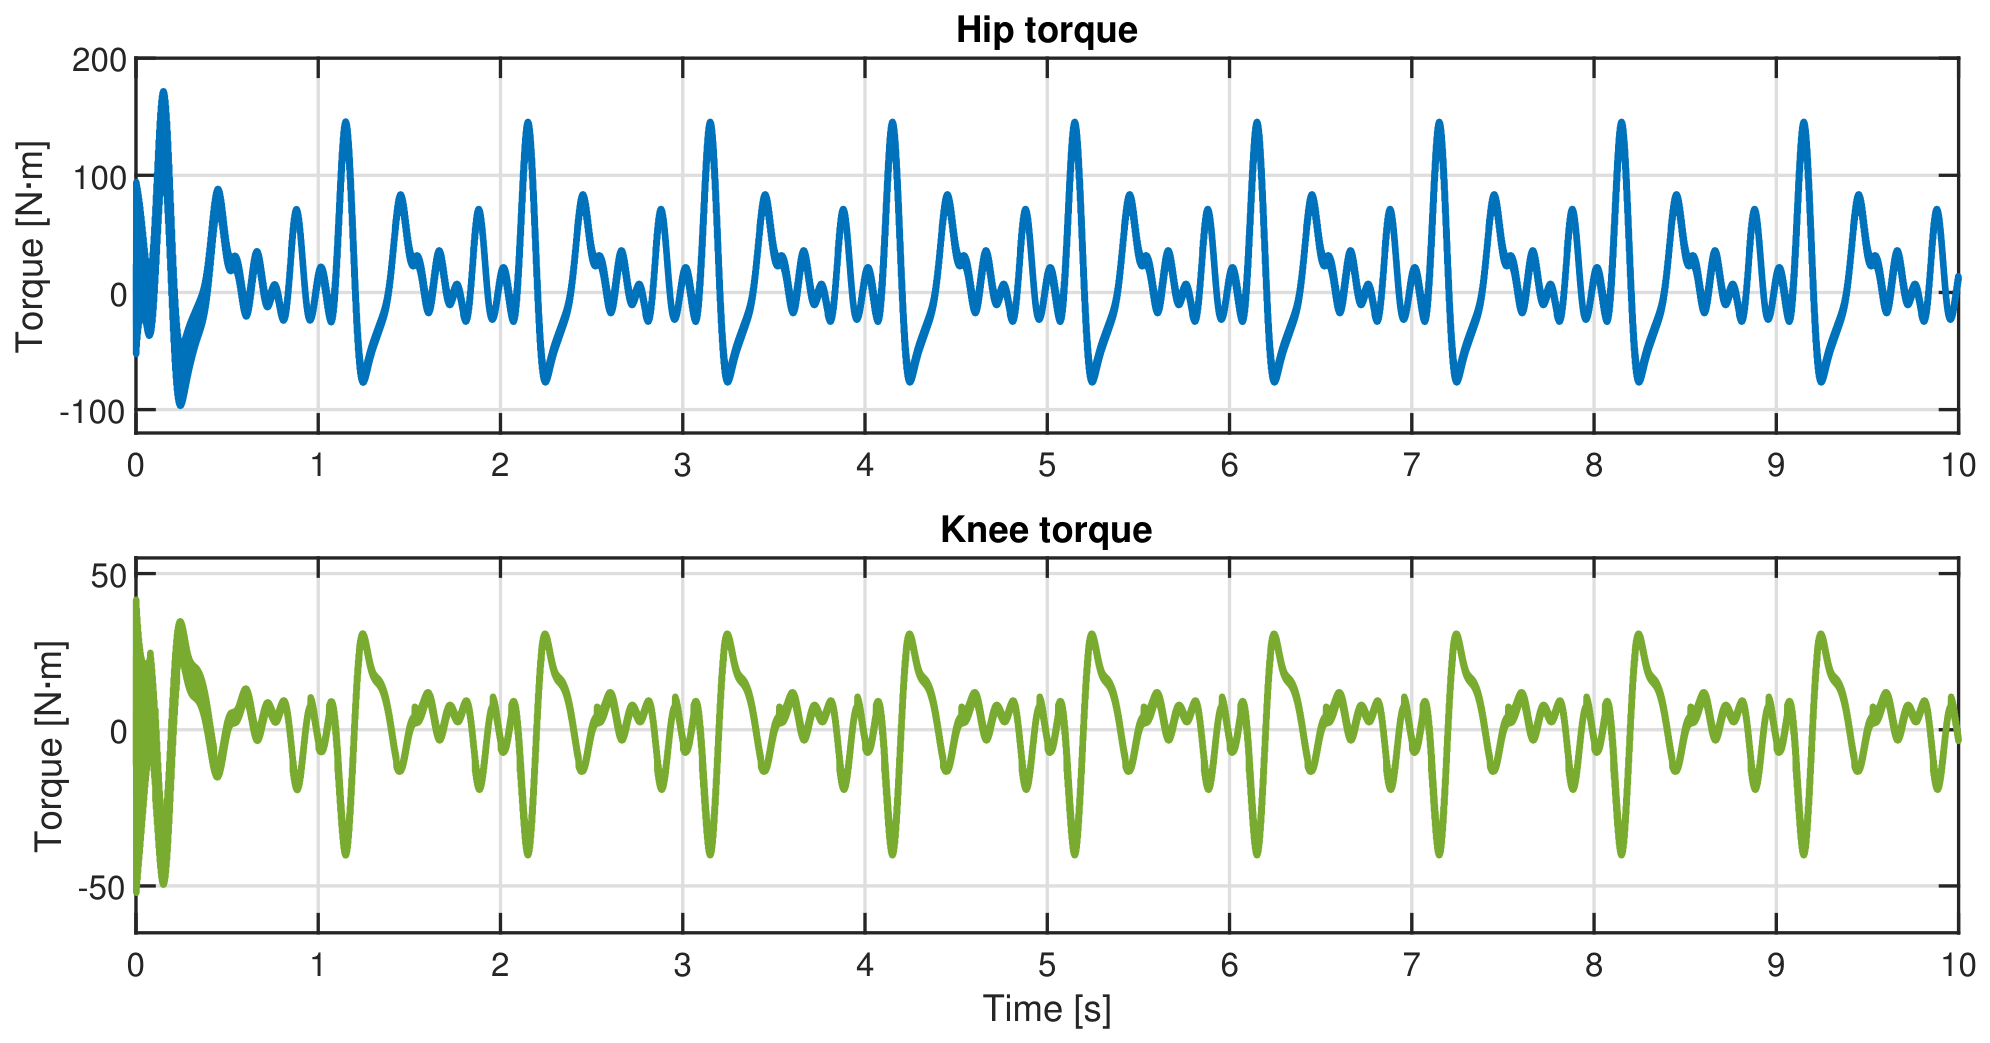
Figure 9 shows the control torques generated at the hip and knee joints of the user. Both signals remained continuous and bounded throughout the simulation without numerical instabilities, confirming that the hierarchical controller did not exhibit a chattering-induced divergence. It should be noted that
and
, as computed in this simulation, represent the total joint torque required to actuate the limb under a full-authority controller with no contribution from residual muscular activity. Consequently, these values are not directly comparable to the 10–30 N·m (hip) and 8–20 N·m (knee) assistive torque ranges delivered by the physical actuation hardware described in
Section 2.2, which is designed to complement, rather than replace, the user’s own muscular effort. This distinction is discussed in
Section 4.
The reported torques correspond to equivalent joint-level control inputs in the dynamic model rather than the direct output torque of the actuation unit. In the proposed cable-driven architecture, these joint-level torques are realized through tensile forces transmitted by Bowden cables and mapped to effective joint moments via joint-dependent moment arms and mechanical transmission ratios, with the exosuit contributing only a fraction of the total torque. A partitioning strategy between muscular and exosuit-delivered torque was identified as a direction for future research.
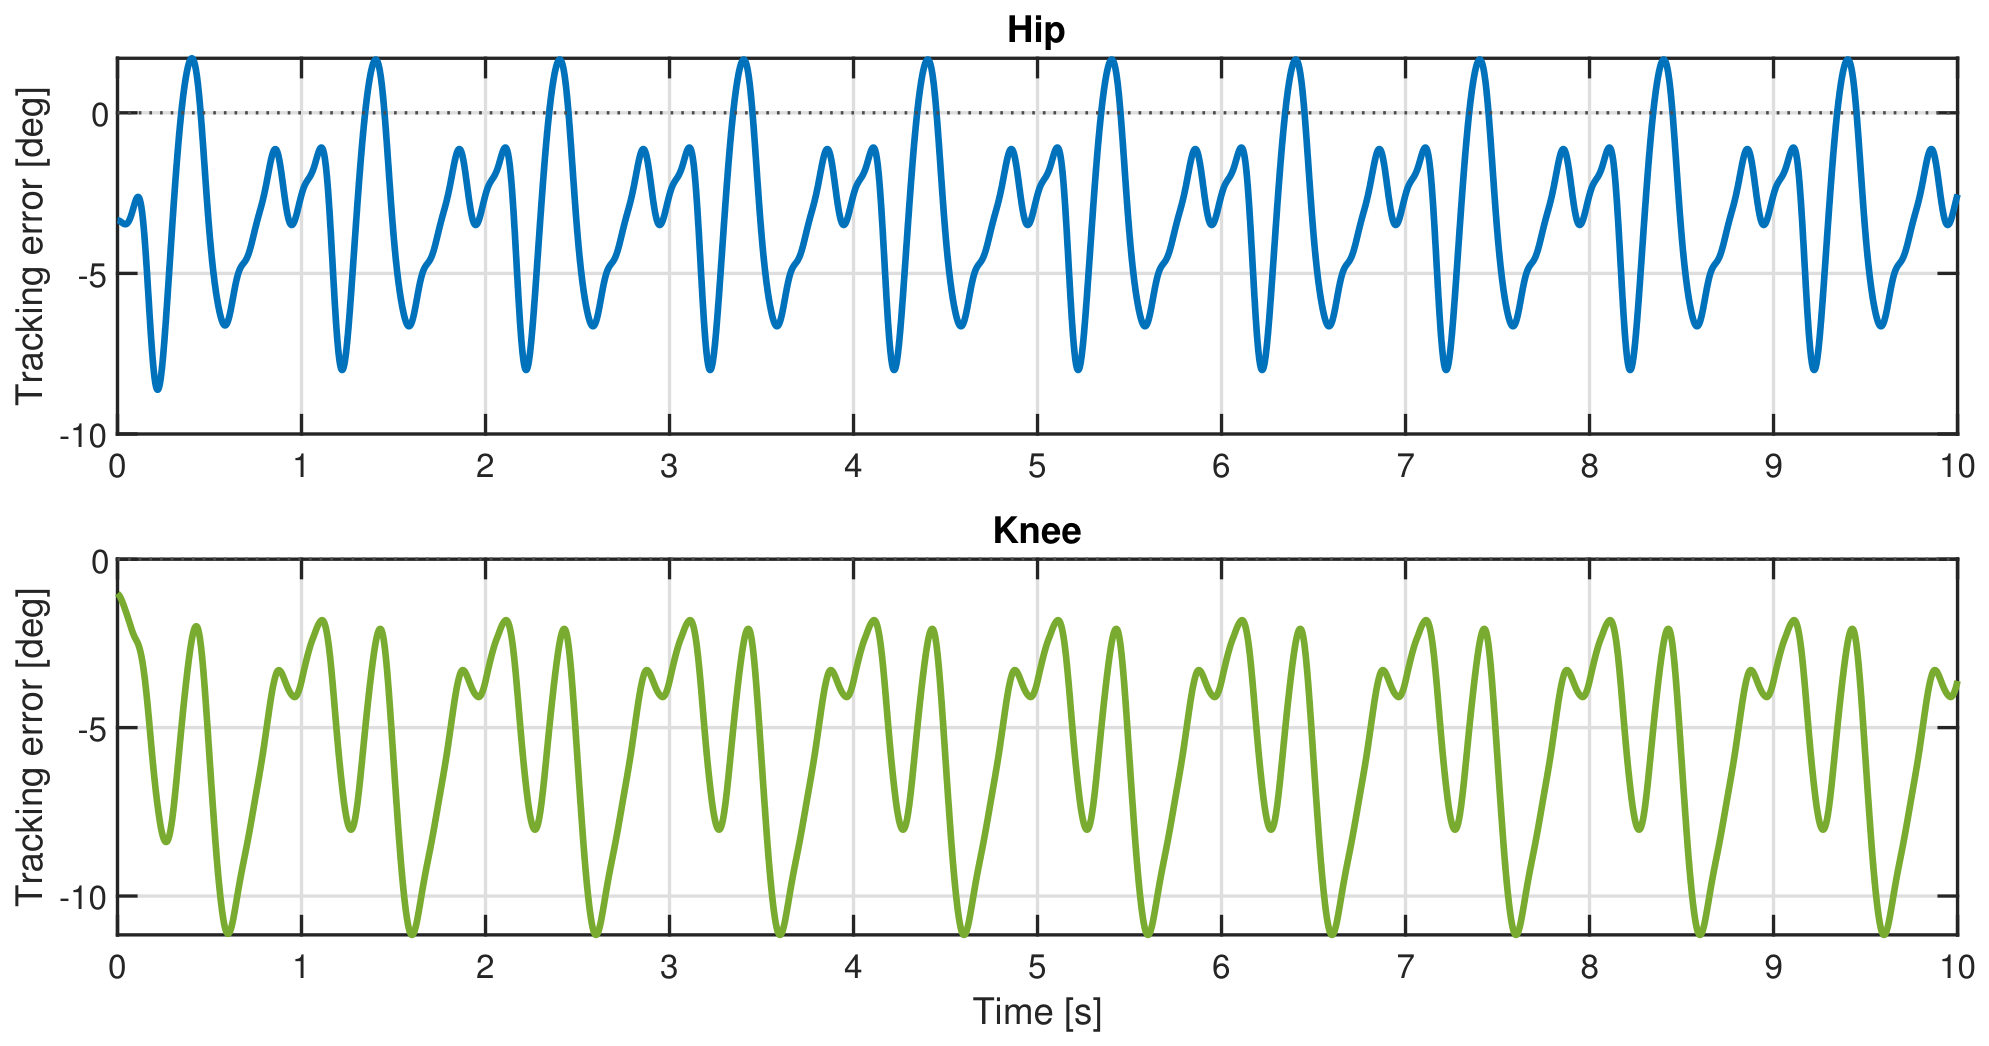
Figure 10 illustrates the tracking errors for both joints. In all cases, the error remained bounded throughout the gait cycle, with larger deviations occurring periodically at each step rather than during a single initial transient. The maximum absolute tracking error reached
for the hip and
for the knee (
Table 4). These bounded errors are consistent with the uniform ultimate boundedness predicted by the stability analysis presented in
Section 2.5.
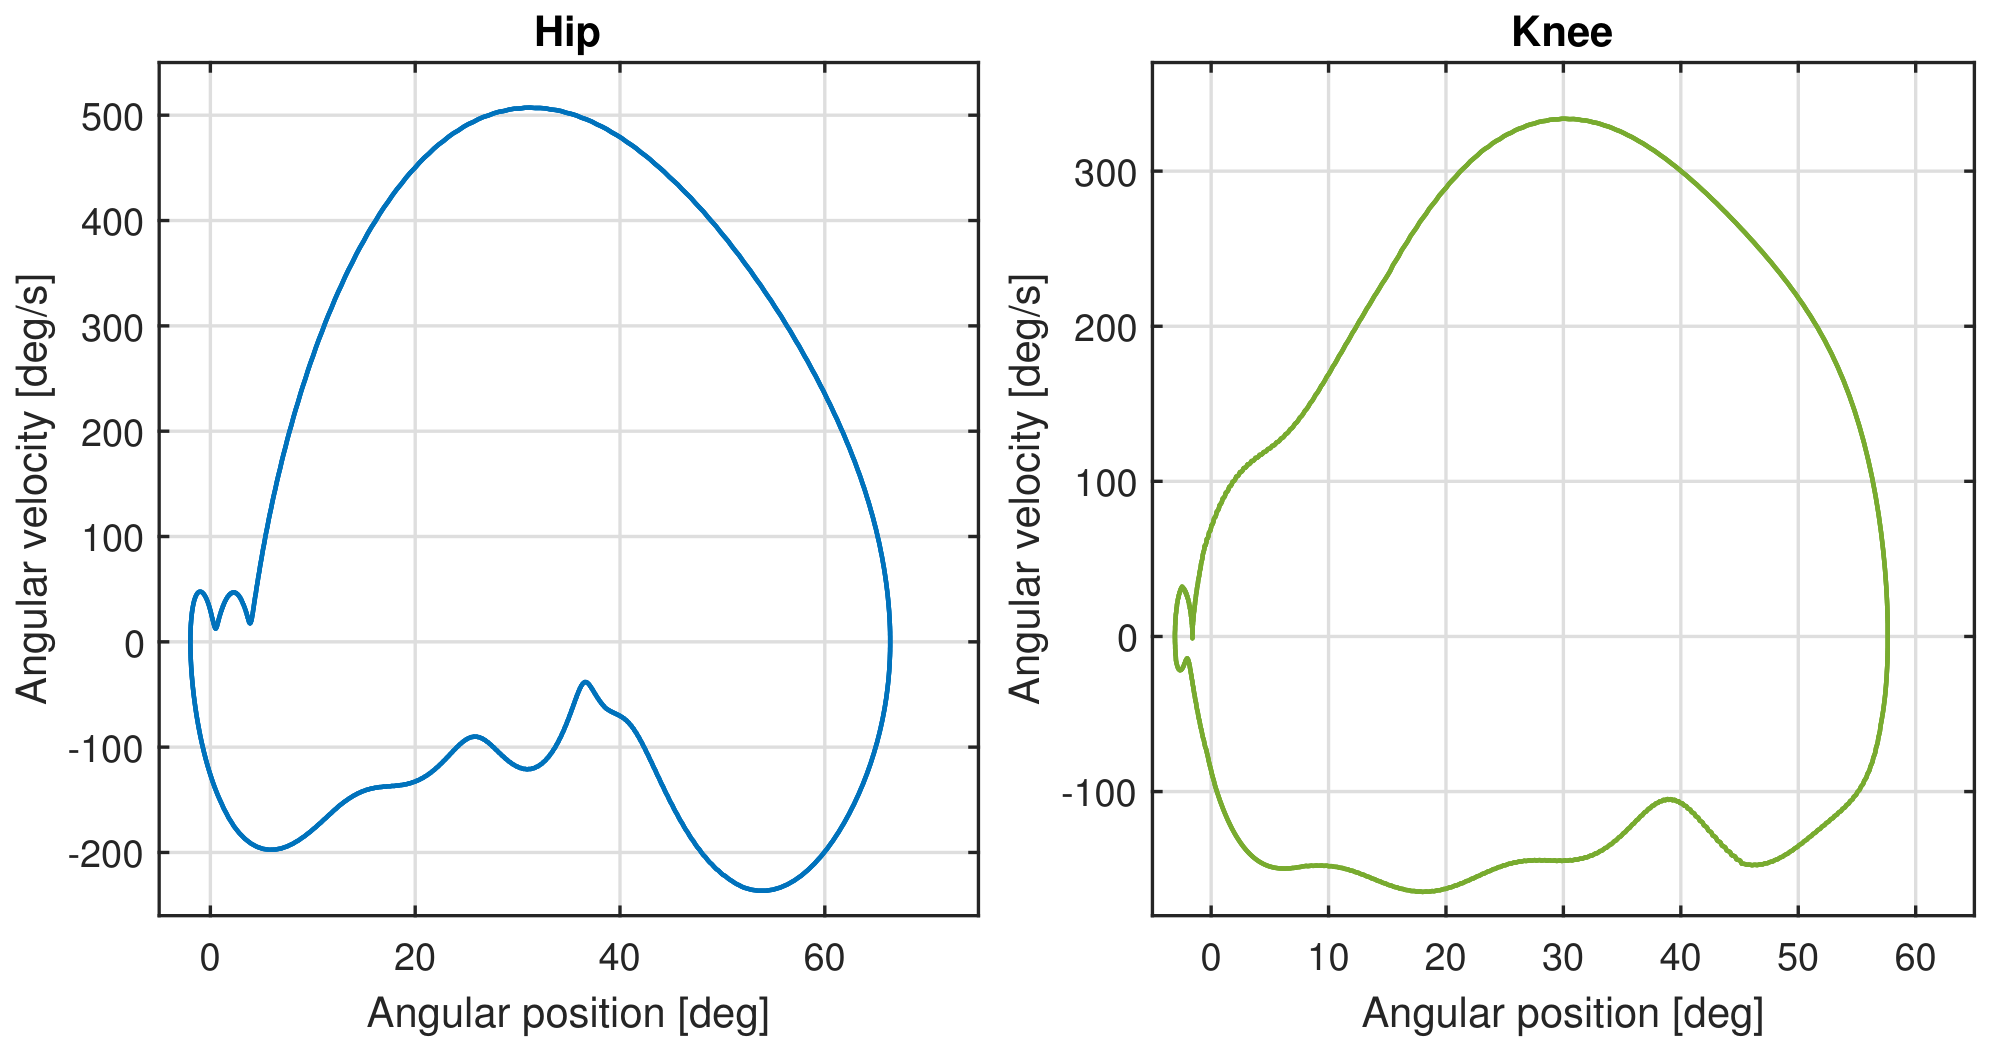
Figure 11 shows the phase plane portraits of the hip and knee joints for the last three simulated gait cycle. To quantify the repeatability of the closed trajectories, the angular position at each peak flexion instant (where the angular velocity crossed zero) was compared across the steady-state gait cycles. The cycle-to-cycle spread of the peak flexion angle (range, max–min) was
for the hip and
for the knee, with corresponding standard deviations of
and
, respectively. These values are several orders of magnitude smaller than the maximum tracking errors reported in
Table 4 (
and
), confirming that the observed closed loops corresponded to a highly repeatable periodic orbit rather than a drifting or diverging trajectory.
Table 4 summarizes the quantitative performance metrics obtained from the MATLAB–Simulink
® simulations, complementing the qualitative trends observed in
Figure 8,
Figure 9 and
Figure 10. The hip and knee joints achieved RMSE values of
and
, respectively, with maximum absolute errors of
and
, respectively, which is consistent with the error bounds qualitatively reported in
Figure 10. The Integral of Absolute Error (IAE) was higher for the knee (
) than for the hip (
), indicating a larger cumulative error over the gait cycle, consistent with its larger RMSE. No overshoot was observed for either joint, confirming the absence of transient excursions beyond the reference trajectory once the initial condition mismatch was removed by aligning the reference phase at
. Because the reference trajectory is periodic, the classical settling time metric is not directly applicable; the tracking error re-exceeds the tolerance band at each gait cycle rather than converging to a single steady-state value. Consequently, the settling-time estimator returned the full 10-s simulation horizon for both joints, and no finite settling time within the simulated window was reported.
The RMS control torque was
N·m for the hip and
N·m for the knee, with corresponding peak values of approximately 200 N·m (hip) and 50 N·m (knee), as shown in
Figure 9. As discussed above, these values represent the total joint torque demanded under full-authority control and are not directly comparable to the 10–30 N·m (hip)/8–20 N·m (knee) assistive range of the physical actuation hardware described in
Section 2.2. Because the RMS metric averages over the full gait cycle, it is necessarily lower than the peak torque and can numerically fall within the ranges reported for other quantities (e.g., the assistive range) without implying an equivalent physical meaning. The peak values, which better reflect the instantaneous actuation demand, remained above the assistive range for both joints.
Regarding the physics-based stage, the transition from MATLAB–Simulink
® to the MuJoCo–ROS2 environment introduced several implementation challenges, including retuning the controller and making numerical adjustments. During the initial tests, discrepancies between the simulation step size in MuJoCo and the control loop frequency in ROS2 resulted in minor oscillations and time delays. To mitigate this, the controller sampling period was reduced from 20 to 5 ms, thereby improving the synchronization between the two environments. In addition, the adjustment of the controller gains helped to stabilize the torque response. After these modifications, the closed-loop simulation achieved coherent joint motion without numerical divergence or actuator saturation while maintaining stability under cable friction and transmission elasticity. Although graphical plots from the MuJoCo simulations are not included in this manuscript, all simulation configurations, controller implementations, and associated datasets are openly available and allow full reproduction of the experiments within the MuJoCo–ROS2 framework at
https://github.com/FerNavaMartinez/Mujoco_ROS2 accessed on 26 August 2026.
Overall, the simulation results indicate that the proposed hierarchical control architecture achieves a stable closed-loop behavior with bounded trajectory tracking for the coupled hip–knee system. The QSMC stage ensures the regulation of angular dynamics within a quasi-sliding regime, whereas the SMC stage compensates for residual errors in the conjugate momentum dynamics. Together, these complementary control mechanisms yield a behavior that is fully consistent with the theoretical analysis presented in this study.
Prototype Validation
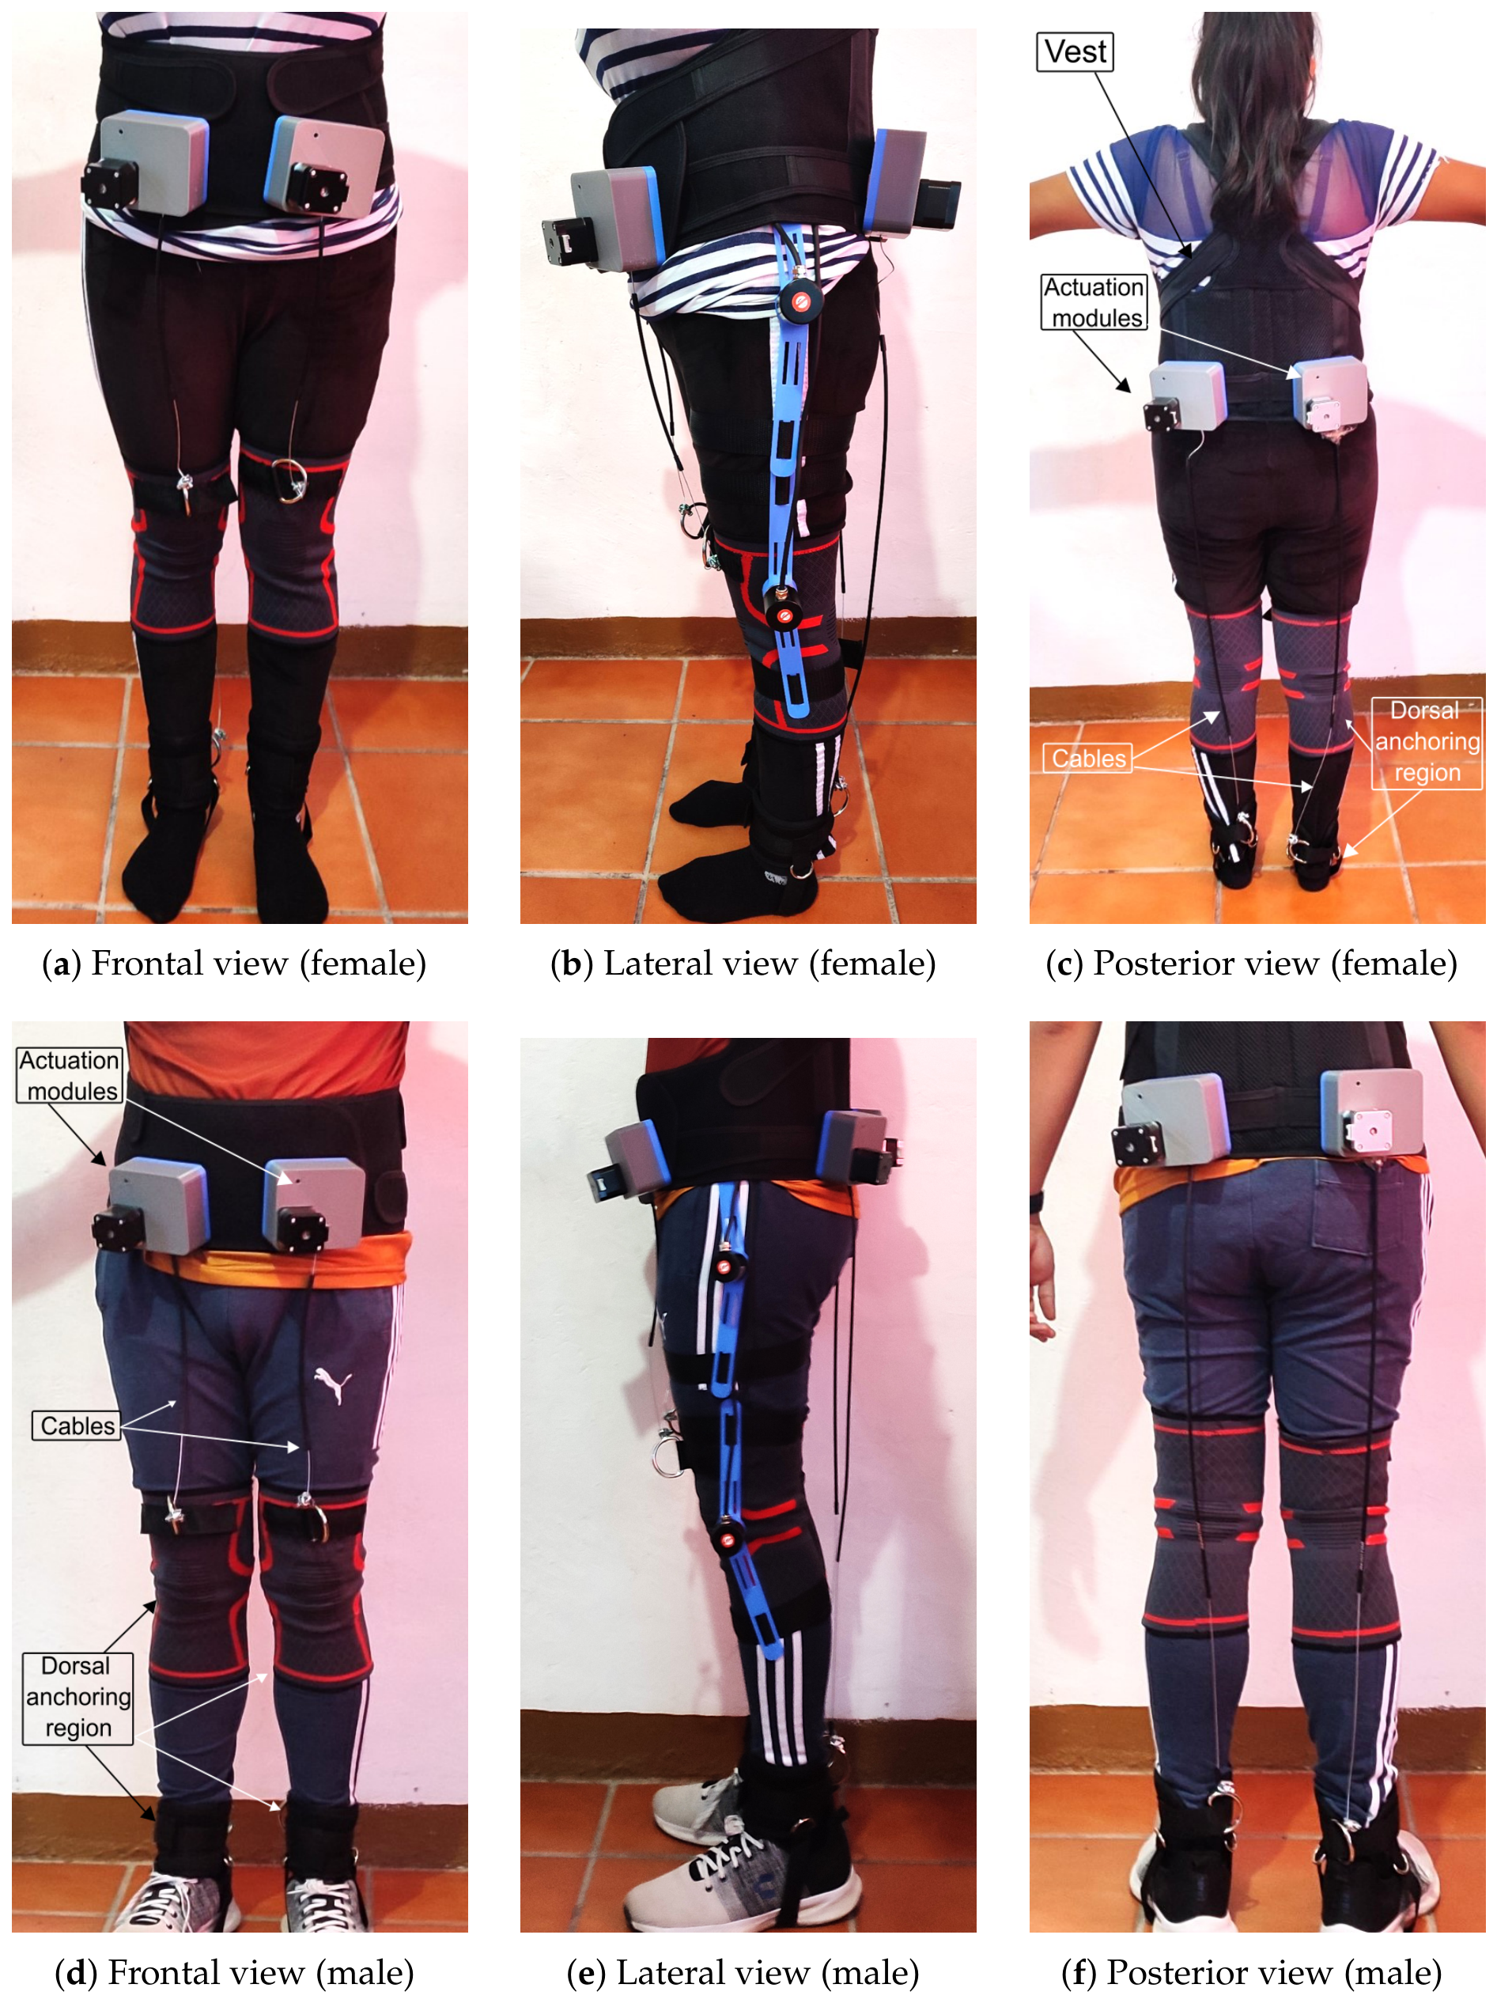
Figure 12 illustrates the developed prototype of the cable-driven soft exoskeleton worn by male and female users, demonstrating its adaptability to the different anthropometric characteristics of the users. The modular architecture allows the system to be adjusted for variations in height, body mass, and morphology, making it suitable for both male and female users within the operational range of the device. The mechanical configuration integrates dual waist-mounted actuator modules that transmit motion to the hip and knee joints via Bowden cables, ensuring efficient force transfer while maintaining a lightweight. Elastic textile interfaces and adjustable straps provided an ergonomic fit and stable alignment with the anatomical axes of the joints. In the lateral view, the placement of the rotary encoders can be observed; these components function as goniometers anchored at the hip and knee joints to measure the angular displacement of the limbs, supporting the calibration and subsequent validation of motion tracking.
At this stage, the prototype represents the mechanical development phase, preceding electronic integration, and serves as the foundation for subsequent experimental validation, and control implementation in future research. For the fitting trials shown in
Figure 12, NEMA-17HS4401S stepper motors (255 g, 42.3 × 42.3 mm cross-section, 38 mm body length) were installed inside the actuation-module housings as non-functional placeholders for the DC gearmotors specified in
Section 2.2 (Pololu 37D, 10:1, ≈190 g, ⌀37 mm, 50 mm body length), selected for their ready availability at the time of prototyping; no electrical wiring, driver, or control signal was connected to these units and no actuation was performed. The placeholder units were approximately 34% heavier and had a larger cross-sectional footprint than the specified DC gearmotors, but were shorter in length. Consequently, the ergonomic fit and weight-distribution observations reported here characterize only the textile-mechanical frame and do not capture the true distal inertia or dynamic wearability of the fully actuated system, because the DC gearmotors and internal gear-train, which together account for the majority of the distal mass (
Table 3), were represented only by non-functional, heavier placeholders in the tested prototype.
These qualitative observations support the structural feasibility of the proposed soft exoskeleton, demonstrating that the modular structure can be adjusted to accommodate users of different body types without evident misalignment of the joint axes. The current prototype also demonstrates the structural feasibility of the cable-driven actuation concept and the mechanical robustness of the textile interfaces under static load conditions before the integration of electronic subsystems. Together, these findings establish a preliminary basis for the integration of control electronics and sensing modules, which will enable dynamic testing and quantitative, instrumented assessment of assistive performance, ergonomic comfort, and joint alignment in future studies.
4. Discussion
The analytical simulations provide numerical evidence supporting the stability and tracking performance of the proposed hierarchical QSMC–SMC control strategy, formally supported by the Lyapunov-based stability analysis (
Section 2.5) and evaluated under nonlinear coupling, gravity, and bounded disturbances in the MATLAB–Simulink
® environment. Within the analytical simulation environment, the combination of QSMC regulation for angular dynamics and SMC applied to the conjugate momenta enabled stable closed-loop behavior under the nonlinear coupling, gravity, and inertial effects inherent to the double-pendulum model, achieving RMSE values of
(hip) and
(knee) (
Table 4), which is consistent with the bounded tracking error predicted by the Lyapunov-based analysis. In contrast, the mechanical prototype evaluation was restricted to assessing the structural feasibility and fit of the textile-mechanical frame; it did not constitute an experimental verification of the controller robustness because the electronic actuation and sensing subsystems were not integrated at this stage. A direct quantitative comparison of the proposed strategy with conventional proportional-derivative or adaptive schemes under matched conditions was not performed in this study and is left for future work.
An important aspect of the proposed approach is the energy-based representation of the coupled hip–knee dynamics. The equations of motion were first derived using the Euler–Lagrange formulation and subsequently recast via a Legendre transformation into a Hamiltonian representation in terms of the conjugate momenta (
Section 2.3). This energy-consistent representation facilitates the design of control laws that explicitly account for nonlinear interactions and momentum exchange between joints, which are often neglected in purely kinematic or simplified dynamic models. Within this framework, the hierarchical control structure enables the regulation of angular trajectories while compensating for residual dynamic effects at the momentum level, resulting in bounded tracking errors and repeatable periodic motion, which is consistent with the uniform ultimate boundedness predicted by the stability analysis in
Section 2.5.
It should be emphasized that the joint torques
reported in
Section 3 represent the total torque required to actuate the limb under a full-authority controller, with no contribution from residual muscular activity, because the analytical model does not include a representation of the human musculoskeletal system. Consequently, the reported RMS torque values (46.569 N·m hip, 13.582 N·m knee) are not directly comparable to the 10–30 N·m (hip)/8–20 N·m (knee) assistive torque range delivered by the physical actuation hardware described in
Section 2.2, which is designed to complement, rather than replace, the user’s own muscular effort. A torque-partitioning strategy between the residual muscular contribution and exosuit-delivered assistance, informed by electromyographic or musculoskeletal modelling data, is required before the simulated torques can be mapped onto assistive-mode operation and is identified as a priority for future work.
Preliminary physics-based simulations were also conducted in the MuJoCo–ROS2 environment to explore the feasibility of the proposed control architecture under contact interactions and compliant tendon elements. However, achieving stable closed-loop operation in this environment required reducing the control loop period from 20 to 5ms and retuning the controller gains relative to the MATLAB–Simulink® configuration, reflecting the sensitivity of the discontinuous control law to discretization and to the additional contact and compliance dynamics present in MuJoCo. Because quantitative tracking and torque data from this stage are not reported here, these results should be regarded as a qualitative, preliminary indication of implementability rather than confirmation that the control architecture performs equivalently across both simulation environments; a quantitative matched-condition comparison is left for future studies.
The mechanical prototype demonstrated that the cable-driven architecture could be physically implemented and mounted on users with different anthropometric profiles within the targeted height and body mass ranges, based on qualitative visual inspection. These observations support the mechanical integrity and structural feasibility of the design prior to the integration of electronic actuation and sensing elements; however, they do not constitute a quantitative validation of ergonomic comfort or fit, which was not assessed in this study.
To contextualize the proposed system within the current state-of-the-art,
Table 5 provides a qualitative comparison of the present design with three previously cited soft or compliant lower-limb exoskeletons. Unlike the rule-based and admittance-driven strategies employed in [
9,
12], this study introduces an energy-based Hamiltonian representation combined with a hierarchical sliding-mode architecture. Although mathematically equivalent to the Euler–Lagrange formulation, this canonical, momentum-based state representation is particularly well-suited to the design of the proposed SMC stage, which acts directly on the conjugate-momentum dynamics, in contrast to admittance-based schemes that regulate velocity or force directly. However, this theoretical formulation has only been validated numerically so far, as in [
32], whereas designs such as [
9,
12] have already undergone physiological or clinical validation in human subjects. This contrast identifies experimental validation, rather than model sophistication, as the primary axis along which the present study should progress in the subsequent stages.
Despite these encouraging results, this study had several limitations. First, the analytical model represents each limb as a two-link pendulum restricted to swing-phase dynamics without explicitly representing foot-ground contact; consequently, the reported torques and kinematics should not be extrapolated to stance-phase or full-gait-cycle loading conditions, where ground reaction forces substantially alter the joint moment profile. Second, no experimental measurements of joint torques, cable forces, or real-time sensor feedback were conducted, and the correspondence between the total actuation torques reported in this study and the torque that the physical actuator would need to deliver as assistance remains to be established, as discussed above. Third, the nonlinear friction and elastic hysteresis inherent in the Bowden cable transmission were not experimentally characterized in this study. Although the SMC stage is designed to absorb bounded matched uncertainties of this kind, future work will include a dedicated calibration procedure using displacement measurements on the physical prototype to update the friction and compliance parameters of the dynamic model. Therefore, future work will focus on integrating embedded actuation and sensing hardware, incorporating actuator constraints and a human torque contribution model, and pursuing experimental validation under dynamic walking conditions, including stance-phase loading. Additional studies will address human–exoskeleton interaction aspects, including metabolic cost reduction, user comfort, and long-term adaptability across different gait patterns.
5. Conclusions
This study presents an integrated modelling, control, and mechanical design framework for a cable-driven soft exoskeleton intended for lower-limb rehabilitation assistance. Lower limb swing-phase dynamics were derived using the Euler–Lagrange formulation and subsequently recast via a Legendre transformation into a Hamiltonian representation in terms of the conjugate momenta, thereby providing an energy-consistent and physically interpretable description of the coupled hip–knee system under tendon-driven actuation. This representation enables the explicit modelling of nonlinear coupling and momentum exchange, which are often neglected in simplified dynamic and kinetic approaches.
Building upon this model, a hierarchical control architecture combining the QSMC for angular regulation and SMC for conjugate momentum dynamics was developed to compensate for the nonlinear coupling, gravitational effects, and tendon elasticity inherent in the system. The cascaded structure of the controller exploits the separation between the angular and momentum dynamics, making it particularly suitable for compliant and cable-driven wearable systems. A Lyapunov-based stability analysis was conducted to formally establish the asymptotic stability of the ideal closed-loop system and derive explicit gain conditions that ensure robust tracking in the presence of bounded disturbances. For practical implementation, the discontinuous switching term in the outer QSMC loop was replaced with a saturation function, resulting in quasi-sliding behavior and uniform boundedness of the system trajectory.
In parallel, a compact winch-based actuation module was designed and geometrically optimized using a genetic algorithm to reduce the distal mass while preserving mechanical robustness and ergonomic wearability. Relocating the actuation units to the torso and employing optimized gear transmission contribute to improved ergonomics and more natural lower-limb motion, both of which are critical aspects of wearable robotic systems.
Simulations performed in MATLAB–Simulink® demonstrated bounded closed-loop tracking, with RMSE values of (hip) and (knee) over a ten-step gait cycle. The associated RMS control torques (46.569 N·m hip, 13.582 N·m knee) correspond to the total joint torque required under full-authority actuation and are not directly comparable to the assistive torque range of the physical hardware. Establishing this correspondence requires a torque-partitioning model between the residual muscular contribution and exosuit assistance, which is a priority for future work. Preliminary physics-based simulations in the MuJoCo–ROS2 framework indicated that the control architecture remains implementable under contact interactions and cable compliance, although gain retuning was required relative to the MATLAB–Simulink® configuration, and quantitative performance in this environment was not evaluated in detail; a matched-condition quantitative comparison is left for future work. The mechanical prototype supported the structural feasibility of the proposed actuation concept for users with different anthropometric characteristics based on qualitative fit assessment, and remains to be quantitatively validated for ergonomic comfort and adaptability.
Overall, this study provides a coherent, simulation-validated approach to the modelling and control of cable-driven soft exoskeletons, in which energy-based dynamics, hierarchical nonlinear control, and mechanically informed design are integrated into a consistent framework. Closing the gap between the total actuation torques analyzed here and the assistive torques deliverable by the physical hardware, together with the integration of embedded electronics, sensor instrumentation, and systematic evaluation of human–exoskeleton interaction during dynamic gait, remain the central objectives for the experimental phase of this work.




 ,