Article

Simulation-Oriented Parameterization of Virtual Human Head-Orientation Behavior Using Wearable IMU Data

Department of Artificial Intelligence, Joongbu University, Goyang 10279, Republic of Korea
Appl. Sci. 2026, 16(17), 8728; https://doi.org/10.3390/app16178728
Submission received: 16 July 2026 / Revised: 27 August 2026 / Accepted: 31 August 2026 / Published: 2 September 2026
(This article belongs to the Section Computing and Artificial Intelligence)

Abstract

Realistic head-orientation behavior contributes to the credibility of virtual human agents in scenario-based simulations. Conventional finite state machine (FSM) agents often rely on manually defined perception rules, producing repetitive head motion patterns that do not reflect action-dependent human behavior. This study derives action-specific head-orientation parameters from head-mounted inertial measurement unit (IMU) recordings collected from 20 participants across six actions and 600 recording sessions. Preprocessed yaw trajectories were segmented into steady-orientation, scanning, and rapid-turn states and summarized using scan amplitude, scan period, directional bias, head-orientation switching interval, reorientation magnitude, and orientation-state proportion. The resulting profiles were applied to an FSM-based virtual human agent. Participant-independent validation used a 20-fold leave-one-subject-out procedure with comparisons against a fixed rule-based agent and a common stochastic agent using one pooled profile for all actions. The action-specific agent outperformed the common stochastic agent across all evaluation metrics. Compared with the rule-based agent, the action-specific agent showed lower switching interval and orientation-state proportion deviations, whereas the rule-based agent showed higher yaw-distribution similarity. Parameter-wise replacement analysis indicated that angular parameters mainly affected yaw-distribution agreement, while switching interval and orientation-state proportion governed their corresponding temporal and compositional measures. The method improves action-dependent temporal and compositional fidelity while retaining explicit FSM control.

1. Introduction

Virtual human agents are used in scenario-based simulation environments for training, decision support analysis, and behavioral evaluation. In these applications, simulation quality depends not only on high-level action selection but also on whether the agent produces plausible perception-related motion over time. Head orientation is one of the most visible cues of perception behavior because it reflects the direction in which a person appears to observe, scan, or respond to the surrounding environment [1,2].
Many virtual human agents are implemented using finite state machines (FSMs), behavior trees, or rule-based control structures [3]. These methods remain useful in simulation because their control logic is explicit, computationally light, and easy to modify. However, perception-related parameters in such models are often assigned manually. As a result, a virtual agent may follow a fixed scan cycle, change direction instantaneously, or repeat an overly regular head motion pattern. Such behavior may be sufficient for simple scenario execution, but it is less suitable when head orientation must vary with the agent’s current action.
Wearable inertial measurement units (IMUs) provide a practical way to record human head motion outside a fixed laboratory setting. A head-mounted IMU can measure yaw, pitch, and roll signals that describe temporal changes in head orientation [4,5]. IMU data have been widely used for human activity recognition and motion analysis, but activity labels alone do not provide the control variables needed for virtual agent simulation. The virtual agent also requires parameters that describe how head direction changes during an action.
Head orientation and eye gaze are related but not equivalent. Large overt changes in viewing direction generally involve head movement, whereas small gaze shifts can occur through eye movement without a corresponding change in head direction. A head-mounted IMU captures the broader directional component of orientation behavior but does not measure visual fixation or covert attention. For FSM-based virtual human simulation, this level of representation is still useful because the yaw direction of a virtual agent can be controlled directly. The practical challenge is to convert measured head-orientation trajectories into explicit parameters that can be inspected, adjusted, and reused in a virtual human model.
In the simulation model, the agent’s field of view is updated according to the head-orientation parameters. At each simulation step, surrounding objects are tested against the current field-of-view range. Objects outside this range, including objects approaching from behind, are treated as outside the agent’s current head-oriented perception field until the head direction changes. This field-of-view test is a simulation assumption based on head orientation rather than a direct estimate of human gaze allocation or visual fixation. The extracted parameters serve as head-oriented perception-control variables, not merely as descriptors of motion shape.
Wearable IMU recordings are used here to derive action-specific head-orientation profiles for FSM-based virtual agents. Preprocessed yaw trajectories are divided into three orientation states, and the resulting parameters are mapped to FSM perception-control variables. The method does not classify human activities from IMU data. It uses measured head motion to parameterize how a virtual agent updates its head direction during an action. Participant-independent leave-one-subject-out (LOSO) validation compares the action-specific agent with a fixed rule-based agent and a common stochastic agent using held-out human recordings.

2. Related Work

Research on virtual human agents has examined behavior representation, motion generation, and interaction control in simulations and virtual environments. Classical virtual human and crowd simulation studies provide the conceptual basis for representing human agents in synthetic environments [1,2]. In practical simulation systems, FSMs, behavior trees, and rule-based control structures are frequently used because they allow designers to define explicit states, transitions, and conditions [3,6,7]. Zhang et al. [7] used behavior trees for autonomous agent control under hybrid constraints. Their work supports the use of structured behavior models, but perception-related parameters still need to be specified for each simulation context.
Data-driven methods have also been used to improve motion quality and behavioral variation in virtual characters. Learning-based methods can generate complex locomotion or control policies from measured or simulated data [8]. Motion capture and virtual reality studies have used measured human behavior to improve motion synchronization and interaction realism in virtual environments [9,10]. These studies mainly address full-body motion reproduction, virtual collaboration, or perceived behavioral realism, rather than the extraction of field-of-view control parameters from wearable head-orientation data.
Wearable IMU-based motion analysis is another closely related research area. IMUs are widely used to measure human movement in unconstrained environments, and orientation signals such as yaw, pitch, and roll are suitable for describing rotational motion of the body or head [4,5,11]. Many wearable sensor studies have used IMU data for activity recognition, motion classification, or movement assessment [12,13,14]. Their outputs are generally intended for recognition or analysis rather than direct control of an FSM-based virtual agent.
Head motion has also been studied as an indicator of attention-related behavior. Prior studies have investigated attention estimation from head motion using wearable sensors, indicating that head movement can provide useful information about attention-related behavior at a coarse behavioral level [15]. Studies on gaze prediction in virtual environments have also examined head-based gaze estimation and the relationship between head and eye movements [16,17,18,19]. In virtual agent and virtual reality research, attention mechanisms, gaze behavior, limited perception fields, and behavioral realism have been studied to improve interaction quality and user experience [10,20]. Head orientation can be used as a coarse representation of overt directional behavior, but it does not directly correspond to visual fixation or eye gaze. Gaze and attention models may also require sensing modalities that are not always available in outdoor or scenario-based simulation data collection.
A direct link between wearable head motion measurements and FSM perception-control variables is still lacking. Virtual agent studies provide interpretable control structures, but their perception parameters are often manually assigned. The method converts measured head-orientation trajectories into action-specific head-orientation parameters for FSM-based virtual agent control. Table 1 summarizes the role of the related research directions in relation to this study.

3. IMU-Derived Head-Orientation Parameterization for Virtual Agents

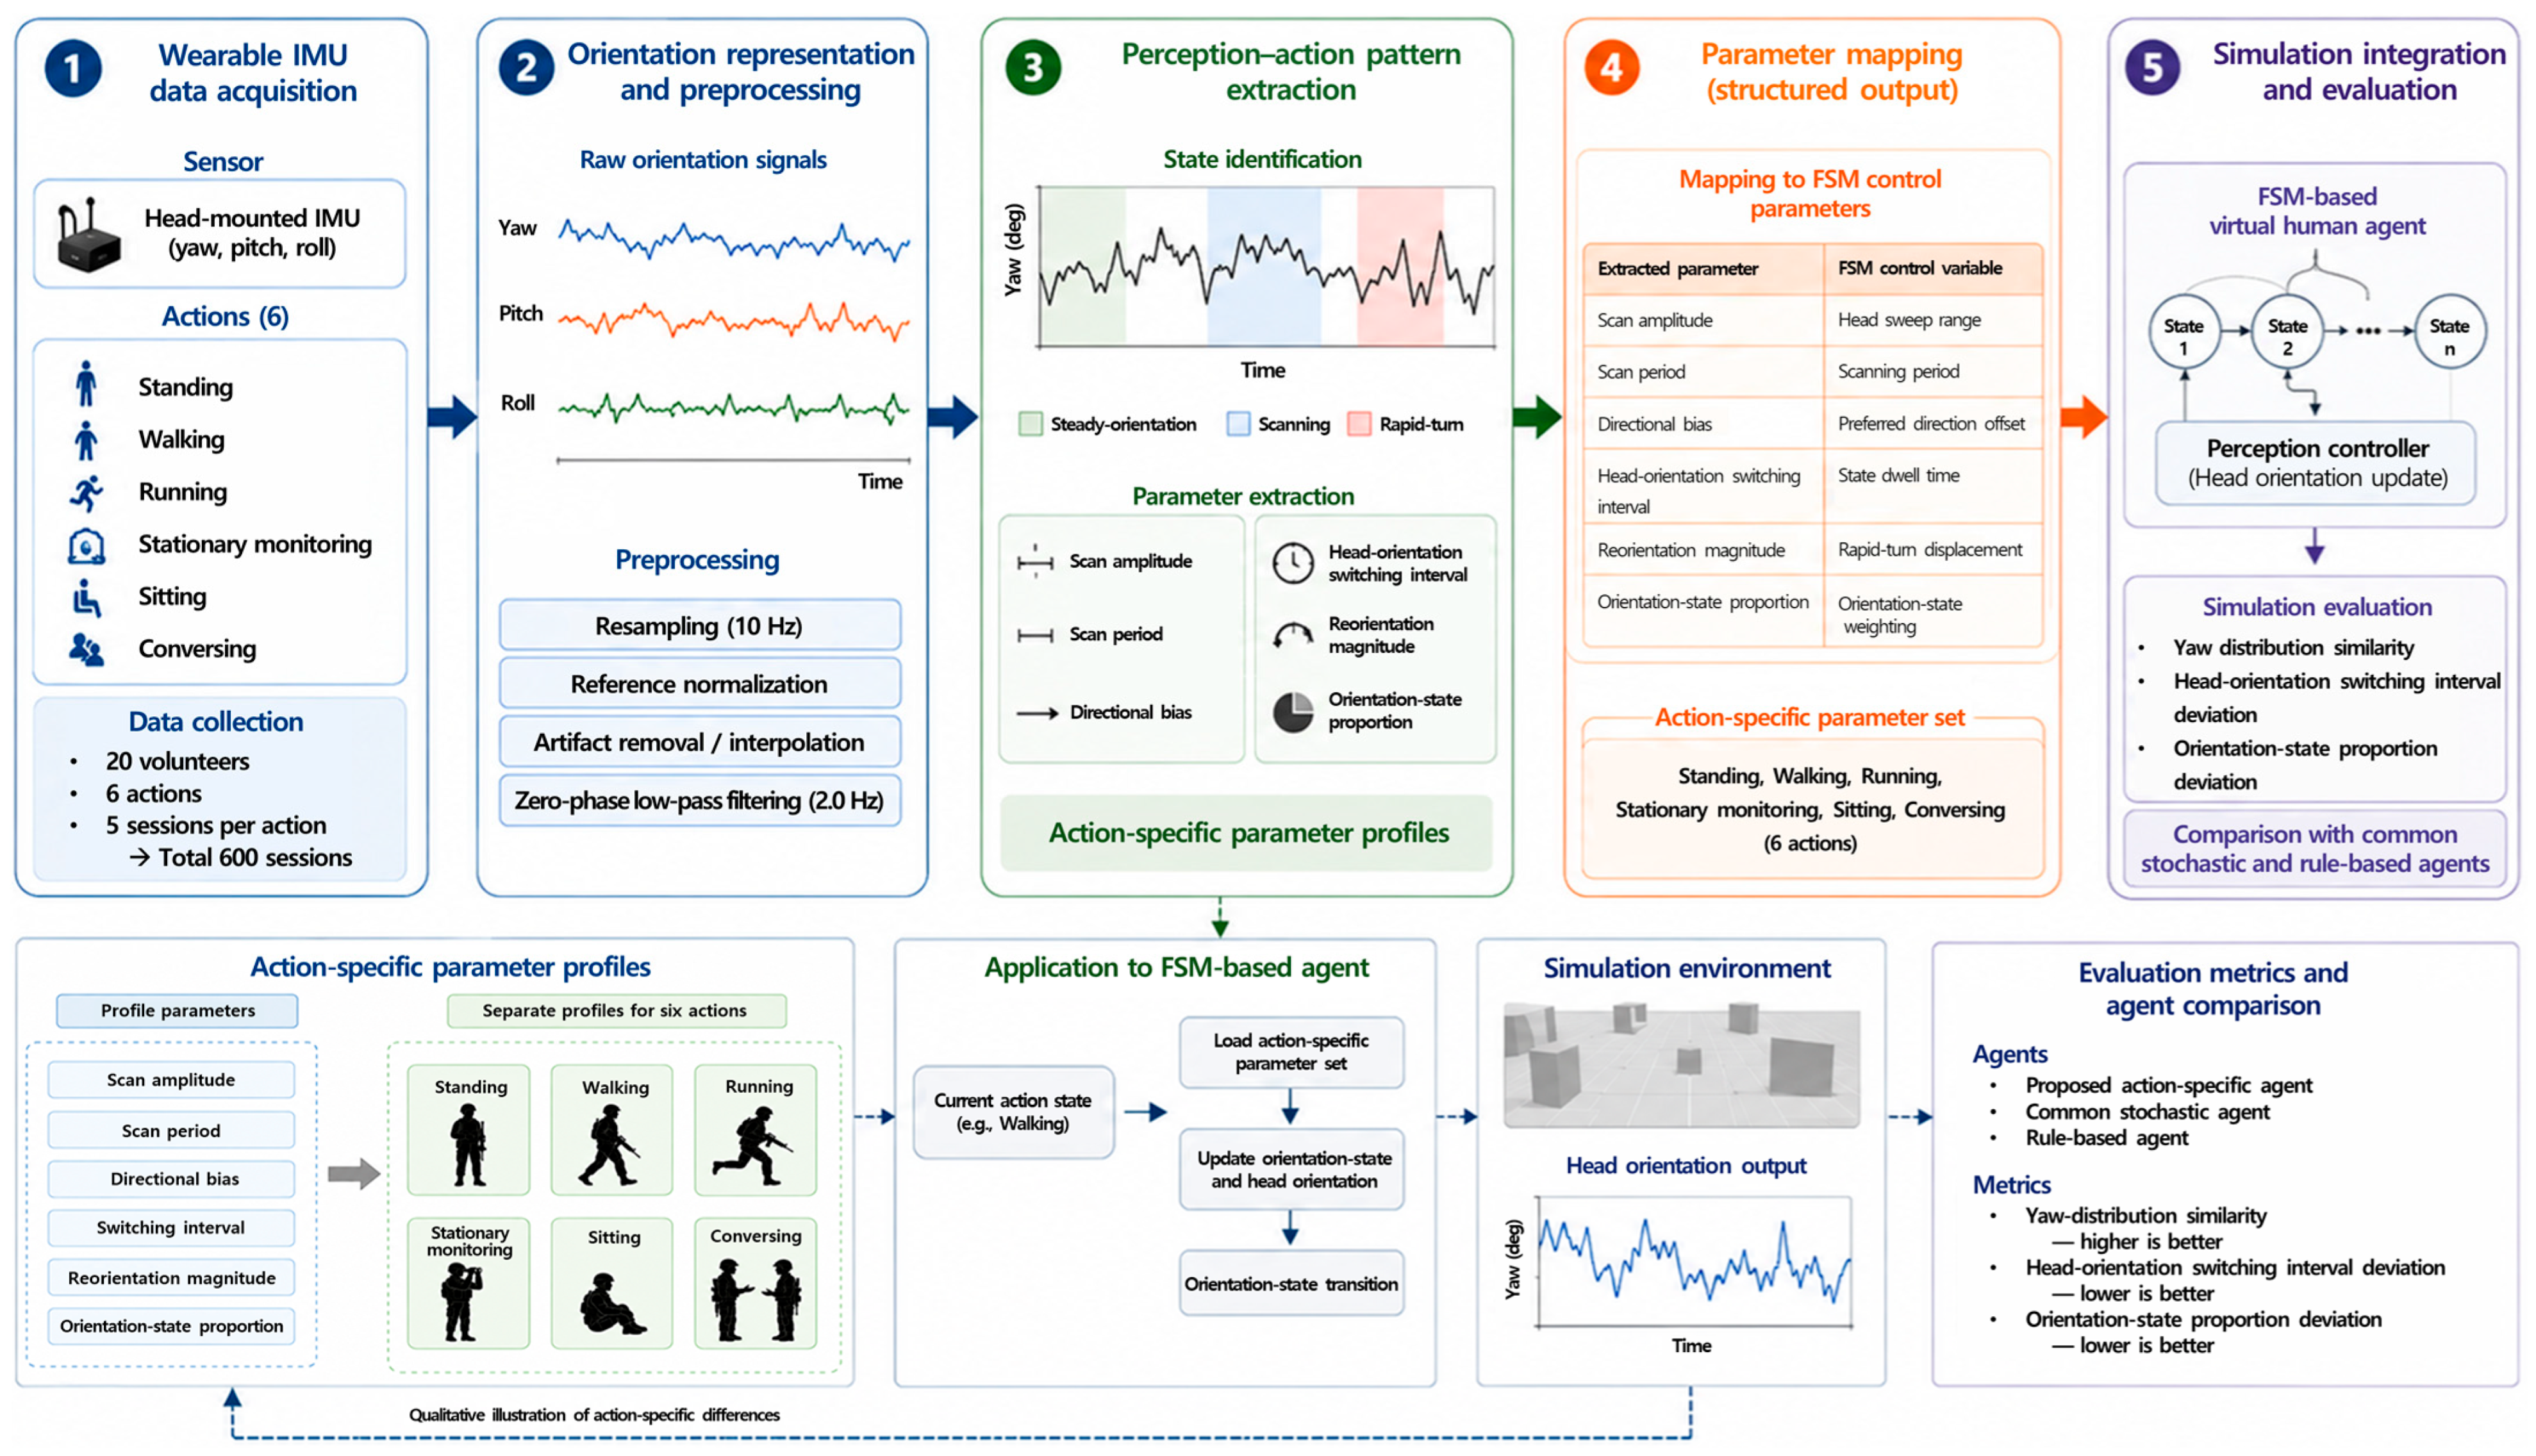
The proposed method converts head-mounted IMU recordings into action-specific head-orientation parameters for FSM-based virtual human agents. The parameters are assigned to the FSM according to the current action state.
Figure 1 shows how the procedure connects head-mounted IMU recording with virtual agent simulation. Head-mounted IMU data are collected during predefined actions and represented as yaw, pitch, and roll signals. The orientation signals are preprocessed to obtain temporally consistent head-orientation trajectories. The yaw trajectory is divided into explicit orientation states, from which action-specific parameters are extracted. The extracted parameters are mapped to FSM perception-control variables and loaded according to the agent’s current action state. The resulting orientation state and head direction are updated during simulation. The simulated behavior is evaluated against held-out human recordings and compared with the common stochastic and rule-based agents.

3.1. Head-Orientation Representation and Preprocessing

In the head-centered coordinate frame, yaw describes left–right head rotation about the vertical axis, pitch describes upward–downward rotation about the lateral axis, and roll describes lateral head tilt about the longitudinal axis. Because the simulation model controls the horizontal perception direction of the virtual agent, yaw is used as the primary signal for detecting scanning and head-orientation switching. Pitch and roll are retained as complementary orientation signals, but they are not used as the main criteria for identifying the three orientation states.
Yaw angles are unwrapped, duplicated or invalid timestamp entries are removed, and each recording is interpolated to a uniform 10 Hz time grid. The median yaw during the initial 1 s is subtracted as the session-level reference orientation. Samples exceeding the 250 deg/s artifact threshold are removed and linearly interpolated. A second-order Butterworth low-pass filter with a cutoff frequency of 2.0 Hz is then applied using forward–backward zero-phase filtering. The 250 deg/s threshold is used only for transient artifact removal, whereas rapid-turn states are identified separately using the action-specific percentile threshold. Sensitivity to nearby filter cutoffs and artifact thresholds is summarized in Appendix A.4.
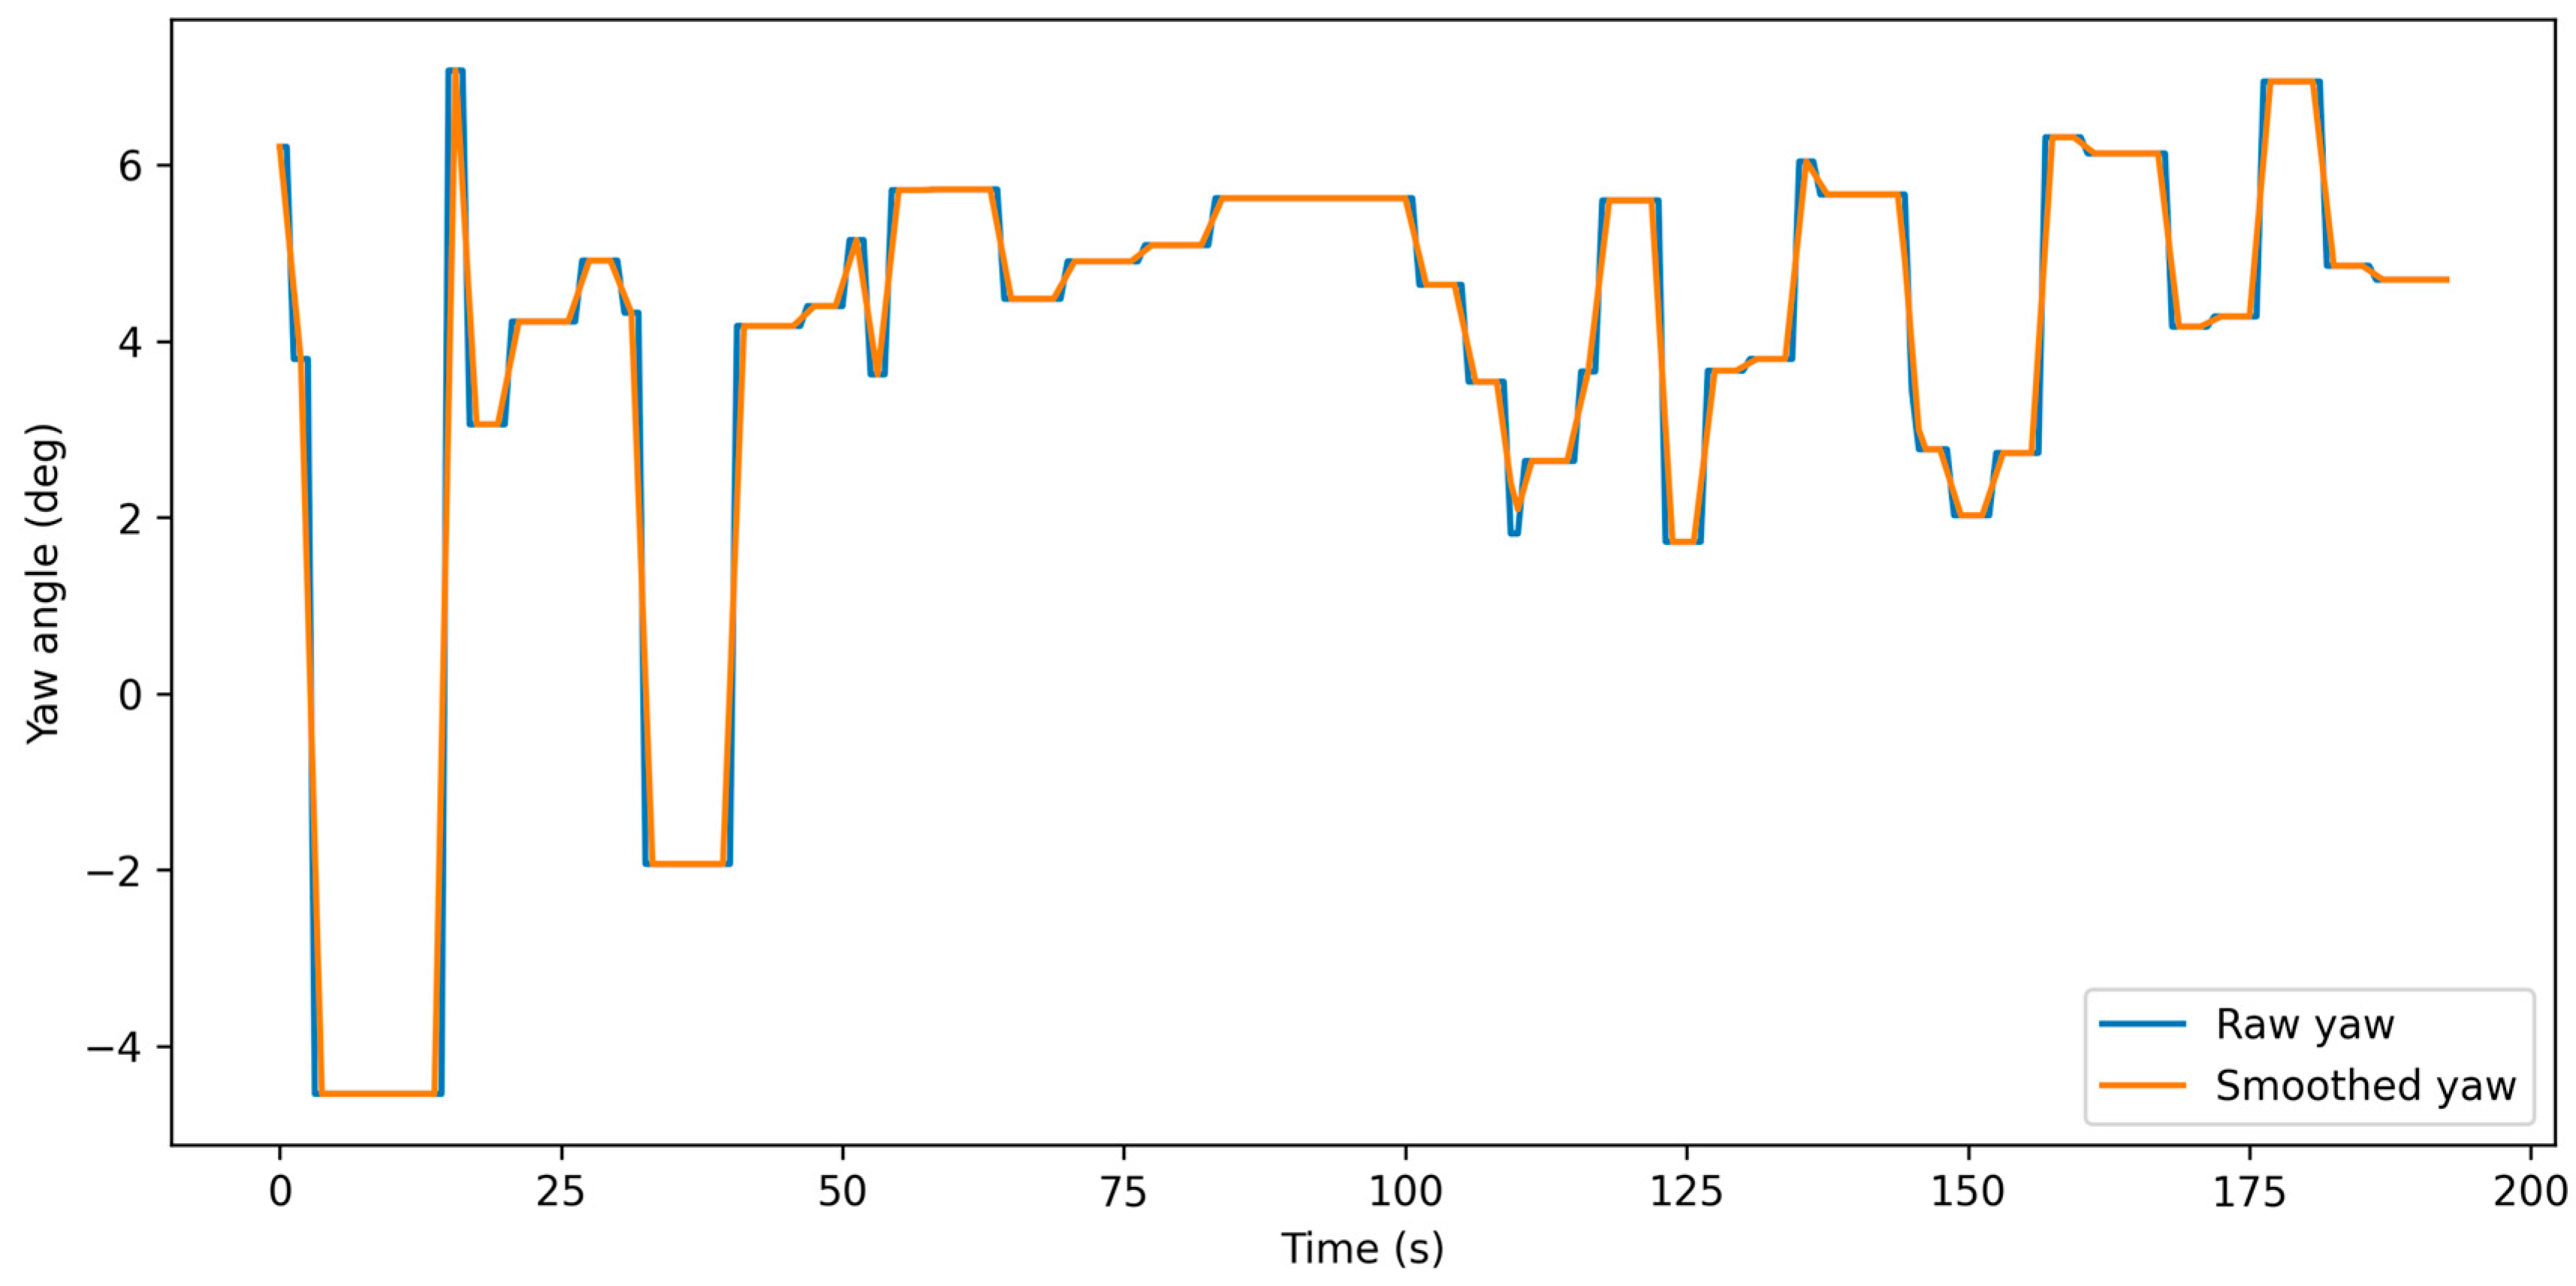
Figure 2 shows a representative yaw trajectory before and after zero-phase low-pass filtering. The smoothed trajectory preserves the low-frequency head-orientation pattern associated with scanning and reorientation while reducing small sensor fluctuations. The preprocessed yaw trajectory is analyzed using 1.5 s windows with 50% overlap. The window duration provides a local interval for estimating yaw variance and directional changes while retaining the temporal resolution needed to identify short head-turn events. The overlap reduces sensitivity to the location of an event relative to the window boundary. Yaw variance and absolute yaw angular velocity are computed within each window.

3.2. Orientation-State Identification

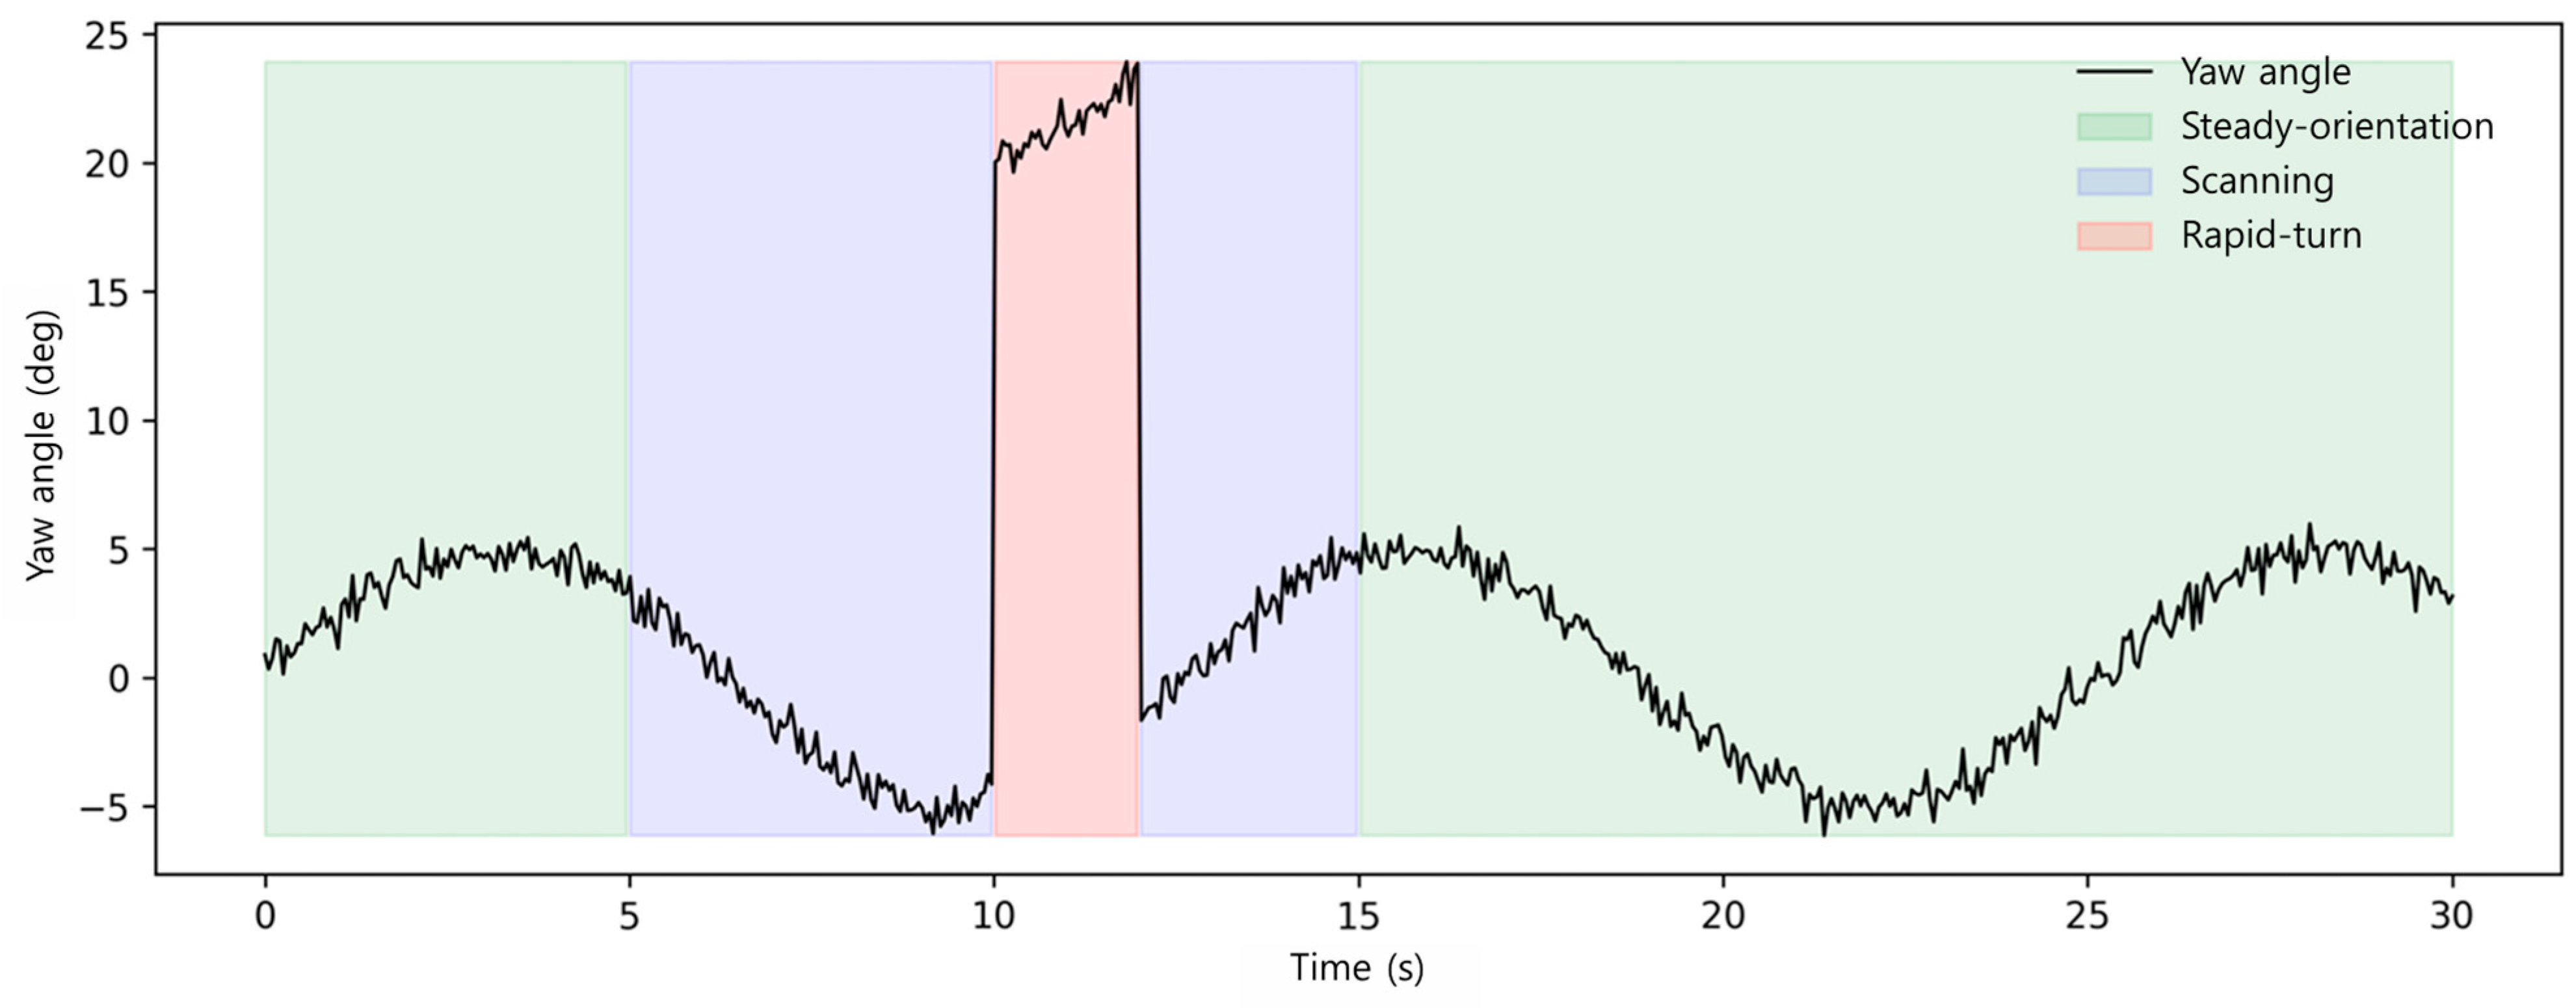
The preprocessed yaw trajectory is segmented into three orientation states: steady-orientation, scanning, and rapid-turn. The steady-orientation state represents windows in which the yaw angle remains within a limited angular range and the angular velocity is low. The scanning state represents repeated directional changes over a bounded angular range. The rapid-turn state represents short-duration windows with high angular velocity and a relatively large yaw displacement.
States are identified using explicit threshold-based rules. For each action, the 30th percentile is used to identify the lower-motion portion of the yaw variance and absolute angular velocity distributions, whereas the 80th percentile is used to isolate short high-velocity reorientation events. These values are action-adaptive operational thresholds rather than universal physiological criteria. The use of separate lower and upper percentiles leaves an intermediate range for scanning behavior and avoids applying the same absolute angular velocity threshold to actions with different motion intensities. For participant-independent validation, these thresholds are determined from the 19 calibration participants in each LOSO fold and are then applied to the held-out participant.
A window is labeled as steady-orientation when both yaw variance and absolute yaw angular velocity are below the lower thresholds. A window is labeled as rapid-turn when the peak absolute yaw angular velocity exceeds the upper threshold. A window that does not satisfy either condition is labeled as scanning when the yaw trajectory contains at least two alternating local extrema. The overlapping windows are used for local state estimation, and the resulting window-level state information is aggregated at the recording-session level for parameter extraction.
The 15° switching threshold is used separately to identify significant changes in head direction when calculating the head-orientation switching interval. It was selected to exclude small fluctuations around the current orientation from being counted as directional switches while retaining clear changes in head direction. As with the percentile criteria, this value is an operational threshold for simulation-oriented parameter extraction rather than a physiological boundary. Sensitivity to the percentile settings, window length, switching threshold, and artifact threshold is examined in Appendix A.4.
Figure 3 illustrates an example of the resulting state segmentation. The shaded regions indicate the three orientation states assigned from the yaw angle dynamics. This segmentation converts the measured yaw trajectory into orientation-state information used for parameter extraction and FSM control. The relative duration of each state can then be compared across actions and used to set the orientation-state proportions of the virtual agent.

3.3. Parameter Extraction and FSM Mapping

The segmented yaw trajectory is converted into a compact set of head-orientation parameters.
A e = m a x   t T e y t m i n   t T e y t ,
where A e denotes the scan amplitude of episode e , y ( t ) is the filtered and normalized yaw angle at time t , and T e is the set of time samples belonging to episode e . The unit of A e is degrees. For each recording session, the scan amplitude is obtained by averaging over all scanning episodes within that session.
Scan period is estimated from the temporal interval between consecutive same-direction extrema in the yaw trajectory. Directional bias is computed as the mean yaw offset from the session-level reference orientation during scanning. The head-orientation switching interval is defined as the elapsed time between consecutive significant yaw direction changes exceeding the predefined switching threshold. Reorientation magnitude is computed from rapid-turn events whose peak yaw angular velocity exceeds the action-specific upper threshold. Orientation-state proportion is obtained by normalizing the duration of each of the three states within each recording session.
Each parameter corresponds directly to an FSM perception-control variable. Scan amplitude determines the horizontal sweep range of the virtual agent’s head. Scan period controls the oscillation timing during scanning. Directional bias shifts the center of the scanning motion when an action shows a consistent directional tendency. During scanning, the center of the oscillatory yaw trajectory is defined as the current reference direction plus the action-specific directional bias. The bias is applied as an offset and is not accumulated after each scanning episode. The head-orientation switching interval determines the dwell time of the orientation state. Reorientation magnitude controls the angular displacement applied during rapid turns. Orientation-state proportion determines the relative occurrence or duration of the three orientation states. Table 2 lists the extracted parameters and their corresponding FSM perception-control variables.
The FSM model separates action execution from head-orientation dynamics. The current action state is determined by the simulation scenario or higher-level decision logic. Within each action state, the head-orientation behavior is generated using the corresponding action-specific parameter profile. The same action state can reproduce the measured temporal variability without requiring every aspect of perception behavior to be embedded in the FSM transition rules.
During simulation, the active action state selects the corresponding parameter profile. The parameter profiles are computed before simulation and loaded as FSM control values. No online model inference is required during head-orientation updates. The controller updates the yaw direction at the simulation update rate of 10 Hz. The orientation state is then updated according to the orientation-state proportions and empirical switching interval distribution extracted from the IMU data. When the active state is steady-orientation, the head direction is maintained within a limited angular range. When the active state is scanning, the head direction oscillates around the bias-adjusted scan center according to the scan amplitude and scan period. When the active state is rapid-turn, an abrupt yaw displacement is applied according to the reorientation magnitude.
During each simulation update, the generated head orientation is used to rotate the agent’s modeled perception field. An object is considered geometrically available to the agent when its relative bearing falls within the assigned horizontal and vertical field-of-view limits. This rule represents a simulation-level visibility assumption and does not indicate measured human gaze allocation or visual fixation.

4. Data Collection and Simulation Evaluation

4.1. Head-Mounted IMU Data Collection

Head motion data were acquired using a wearable inertial measurement unit (WT9011DCL, WitMotion Inc., Shenzhen, China). The sensor integrates a triaxial accelerometer, gyroscope, and magnetometer and provides orientation estimates in yaw, pitch, and roll angles through onboard sensor fusion. The IMU was mounted on the top of a cap worn by each participant. The forward direction of the cap was defined as the reference front direction for head-orientation measurement.
Before each recording session, the sensor was zeroed and calibrated while the participant maintained a forward-facing posture. This posture provided the reference condition for sensor calibration. The calibration procedure was repeated for each recording session to reduce inter-session differences in initial heading and to limit the influence of sensor placement on the subsequent analysis. Because yaw estimation includes magnetometer information, the analysis uses session-relative rather than absolute heading. The forward-facing orientation at the beginning of the session is used as the reference direction. The resulting yaw values are interpreted as relative head orientation rather than absolute compass heading.
Twenty volunteers participated in the data collection. The participant group consisted of 16 male participants and 4 female participants, with an age range of 21–26 years. Data were collected for six actions: standing, walking, running, stationary monitoring, sitting, and conversing. For each action, every participant completed five independently recorded sessions, resulting in 100 sessions per action and 600 sessions in total. Running sessions were limited to approximately 3 min. Walking, standing, stationary monitoring, sitting, and conversing sessions lasted approximately 5–7 min depending on the recording condition. The five sessions were separate recording repetitions rather than subdivisions of a continuous recording.
In the standing condition, participants remained in a waiting posture and generally faced forward. In the walking condition, participants walked along a straight path at a natural pace. In the running condition, participants ran along a straight path without externally imposed head movement instructions. In the stationary monitoring condition, participants remained in place while slowly scanning the surrounding area as if observing the environment. In the sitting condition, participants remained seated in a relaxed posture while allowing ordinary head movements. In the conversing condition, participants engaged in free-form conversation with another person.
No explicit visual stimulus, target-following instruction, or externally imposed scanning rhythm was provided during the standing, stationary monitoring, sitting, or conversing conditions. This arrangement allowed head-orientation behavior to be recorded in action contexts relevant to virtual human simulation without imposing a predetermined scanning rhythm or target-following pattern. Data collection was conducted in an open outdoor area where participants could perform walking, running, stationary monitoring, sitting, and conversing under consistent recording conditions.
Sensor data were recorded as comma-separated values (CSV) files, and timestamp information was used to estimate the effective sampling rate. The effective sampling rate was approximately 8–10 Hz depending on the recording condition. The recorded data included orientation angles and raw inertial measurements, but the proposed method used yaw, pitch, and roll signals because the objective was to parameterize head-oriented perception behavior rather than full-body inertial dynamics.
Each independently recorded session was analyzed using overlapping windows for orientation-state identification and parameter extraction. Window-level labels and parameter values were aggregated at the recording-session level and then summarized by action. Overlapping windows were used for signal-level estimation, whereas the recording sessions served as the repeated measurement units. The five session-level estimates were averaged within each participant and action, and the resulting participant-level estimates were summarized across the 20 participants using the mean and standard deviation.

4.2. Simulation Scenario, Comparison Agents, and Participant-Independent Validation

A simulation scenario was constructed to evaluate head-orientation behavior under the predefined six action states. Each simulation condition corresponded to one of these states. Each simulation condition was run for 120 s and repeated 20 times per action. The environment contained six spatially distributed points of interest, and the same scenario configuration was applied to the proposed action-specific agent, the common stochastic agent, and the rule-based agent. The points of interest were not used as direct target-following commands. Instead, they served as spatial objects whose detectability depended on the current field-of-view direction generated by the head-orientation control model.
Action transitions were externally controlled by the scenario logic. This arrangement isolated the effect of head-orientation control from differences in high-level action selection. The evaluation focused on how the agent updated its perception direction within each action state, not on whether the agent selected different actions.
The rule-based agent was implemented as a hand-tuned FSM agent with fixed perception settings. Its head direction follows a constant scan amplitude and a fixed scan period, and rapid-turn events are generated using a predefined event probability. The rule-based agent does not use IMU-derived action-specific parameters. It is used to evaluate differences in agreement with measured head-orientation profiles.
A common stochastic agent was also included to distinguish the effect of action-specific parameterization from the effect of stochastic motion variation. This agent used the same stochastic state generation mechanism as the proposed agent, but a single parameter profile pooled across all six actions was applied to every action. The pooled profile was estimated only from the calibration participants in each LOSO fold. The comparison between the common stochastic and action-specific agents isolates the effect of using action-dependent parameter profiles.
All three agents used the same simulation duration, update rate, and points of interest for each action condition. The rule-based agent represented fixed heuristic control, the common stochastic agent represented stochastic behavior without action-specific adaptation, and the proposed agent used stochastic variation with action-specific parameter profiles. Participant-independent validation used 20 leave-one-subject-out folds constructed from the existing recordings. In each fold, recordings from 19 participants were used to determine the orientation-state identification thresholds and to construct the action-specific and common stochastic parameter profiles. The remaining participant’s five sessions for each action were used only for evaluation. Each participant served as the held-out participant in one fold.
For the parameter-wise replacement analysis, each action-specific parameter was replaced separately with the corresponding parameter from the common stochastic profile while the other parameters remained action-specific. The same LOSO evaluation procedure was used for each replacement.

4.3. Evaluation Metrics

Three metrics were used to evaluate agreement between simulated and measured head-orientation behavior. The metrics were selected to correspond to the main outputs of the proposed parameterization method: yaw angle distribution, head-orientation switching interval, and orientation-state composition.
Yaw-distribution similarity was computed using the normalized histogram intersection between the measured yaw angle distribution and the simulated yaw angle distribution. A higher value indicates closer agreement between the simulated head-orientation range and the measured reference profile.
D y a w = k = 1 K m i n h k H h k S .
where D yaw denotes the yaw-distribution similarity, K is the number of yaw angle histogram bins, k is the bin index, h k H is the normalized histogram value of the measured human yaw data in the k -th bin, and h k S is the normalized histogram value of the simulated yaw data in the same bin. The histograms are normalized so that the sum of bin values is one. D yaw ranges from 0 to 1, where a larger value indicates closer agreement between the measured and simulated yaw angle distributions.
Head-orientation switching interval deviation was computed as a normalized absolute error between the mean switching interval derived from measured IMU data and that generated in simulation. A lower value indicates closer agreement with the measured temporal persistence of head-orientation states.
E s w i t c h = T ¯ S T ¯ H T ¯ H .
where E switch denotes the normalized switching interval deviation, T ¯ H is the mean head-orientation switching interval derived from the measured human IMU data, and T ¯ S is the mean switching interval generated by the simulated agent. The switching interval is measured in seconds, whereas E switch is dimensionless. A smaller value indicates closer agreement with the measured temporal persistence of head-orientation states.
Orientation-state proportion deviation was computed from the relative proportions of steady-orientation, scanning, and rapid-turn states. The metric measures the mean absolute difference between the measured and simulated orientation-state proportions. A lower value indicates that the simulated agent reproduces the measured state composition more closely.
E s t a t e = 1 3 j = 1 3 p j S p j H ,
where E state denotes the orientation-state proportion deviation, j indexes the three orientation states, p j H is the measured proportion of the j -th state in the human IMU data, and p j S is the corresponding simulated orientation-state proportion. Each orientation-state proportion is computed by dividing the duration of the state by the total duration of the action segment. A smaller E state indicates closer agreement between the measured and simulated orientation-state composition.
These metrics evaluate different aspects of head-orientation behavior. Yaw-distribution similarity measures agreement in directional range, switching interval deviation measures temporal persistence, and orientation-state proportion deviation measures the composition of orientation states. Appendix A summarizes the preprocessing, orientation-state identification, and simulation execution settings needed to reproduce the evaluation.
For participant-level statistical analysis, metric values were averaged across the held-out sessions within each action and then across the six actions, yielding one observation per participant and agent ( n = 20 ). For each metric, the proposed agent was compared separately with the rule-based and common stochastic agents. Normality of the paired differences was assessed using the Shapiro–Wilk test. A paired t-test was used when the normality assumption was satisfied. A Wilcoxon signed-rank test was used otherwise. Statistical significance was assessed at α = 0.05 . Holm correction was applied to the six comparisons. Cohen’s d z was reported for paired t-tests, and rank-biserial correlation r r b was reported for Wilcoxon signed-rank tests. For yaw-distribution similarity, the paired difference was calculated as the proposed agent value minus the comparator value. For the two deviation metrics, it was calculated as the comparator value minus the proposed agent value because lower values indicate better agreement. The same directional convention was used for the effect sizes. Positive values favor the proposed agent, whereas negative values favor the comparator.


5. IMU-Derived Parameter Profiles and Simulation Evaluation

5.1. Extracted Action-Specific Parameters

The extracted head-orientation parameters varied across the six actions. Table 3 presents the resulting action-specific profiles.
Stationary monitoring has the largest scan amplitude and the longest scan period, whereas running has the smallest values for both parameters. Sitting and conversing have relatively high steady-orientation proportions, while walking and running have larger scanning proportions. Directional bias was generally small relative to scan amplitude, although stationary monitoring and conversing showed greater participant-level variation.
Table 3 summarizes the participant-level parameter estimates across the 20 participants. For LOSO evaluation, the proposed agent used fold-specific action profiles constructed only from the 19 calibration participants in each fold. Within each fold, the action state determined which action-specific profile was used.
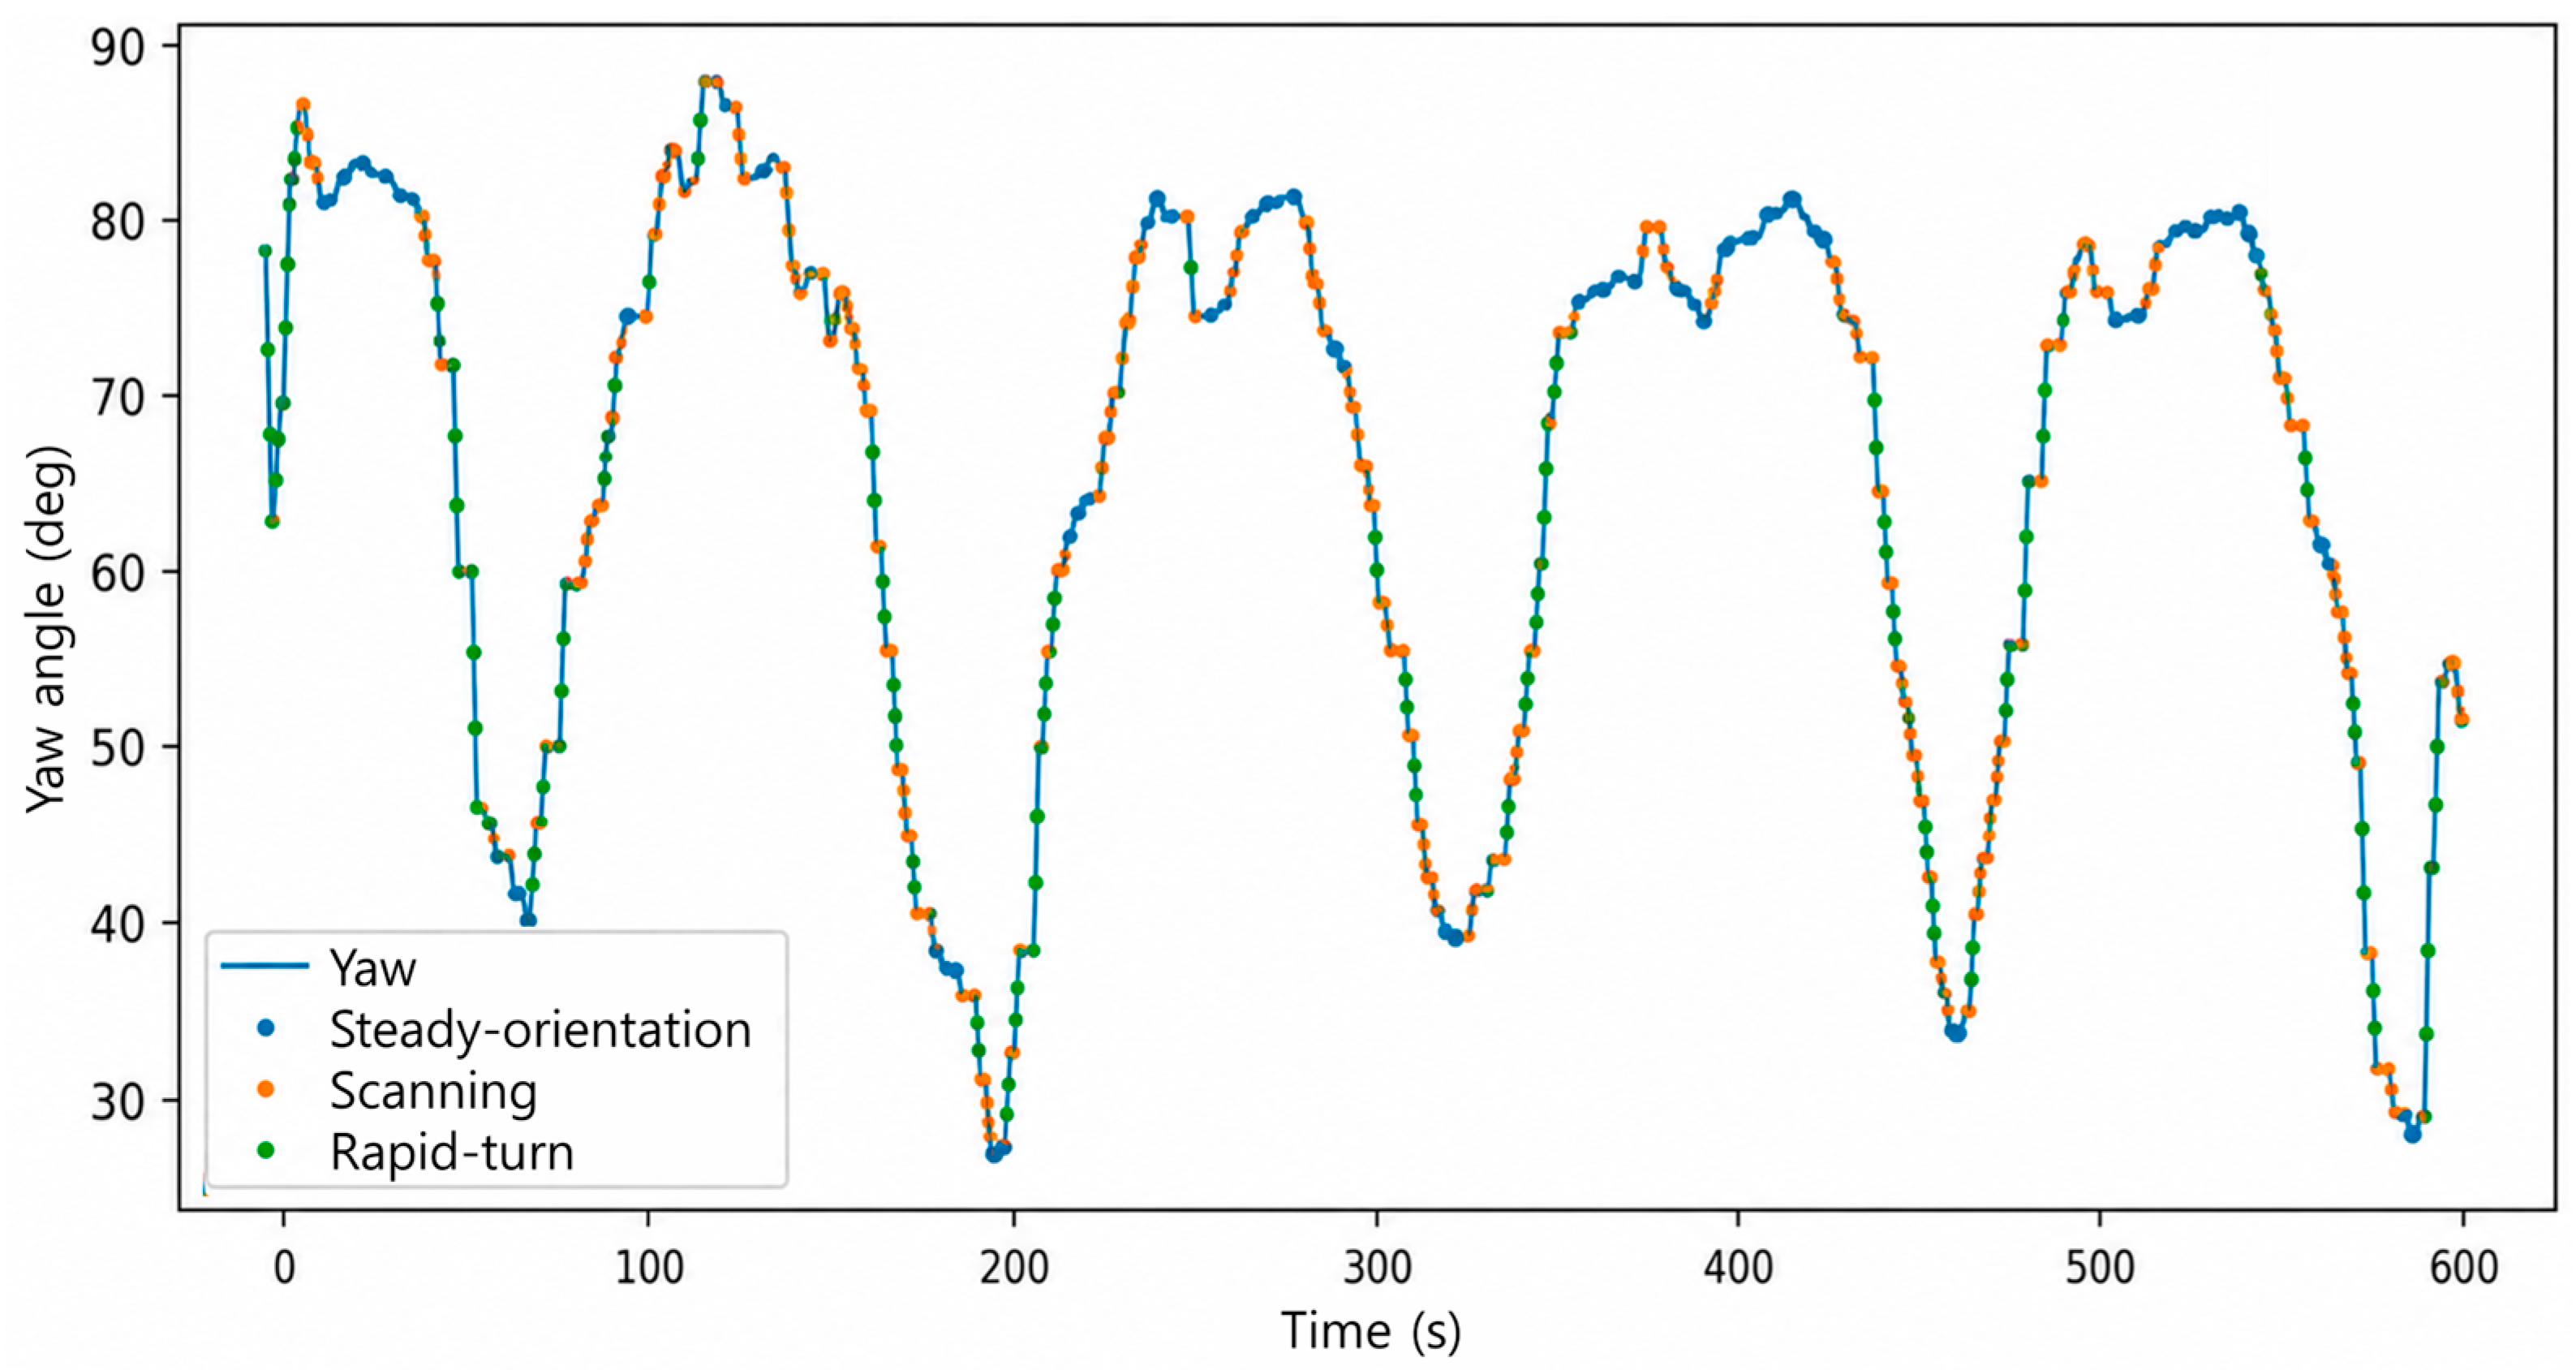
Figure 4 shows representative stationary monitoring segments concatenated for visualization, together with the orientation-state markers derived from the original segments. The concatenated trajectory illustrates broad horizontal scanning and repeated rapid-turn events, which are consistent with the large scan amplitude and scanning proportion reported in Table 3.

5.2. Participant-Independent Simulation Comparison

The proposed action-specific agent was compared with the common stochastic and rule-based agents under the same simulation scenario. Performance was evaluated against the held-out recordings using the three agreement metrics.
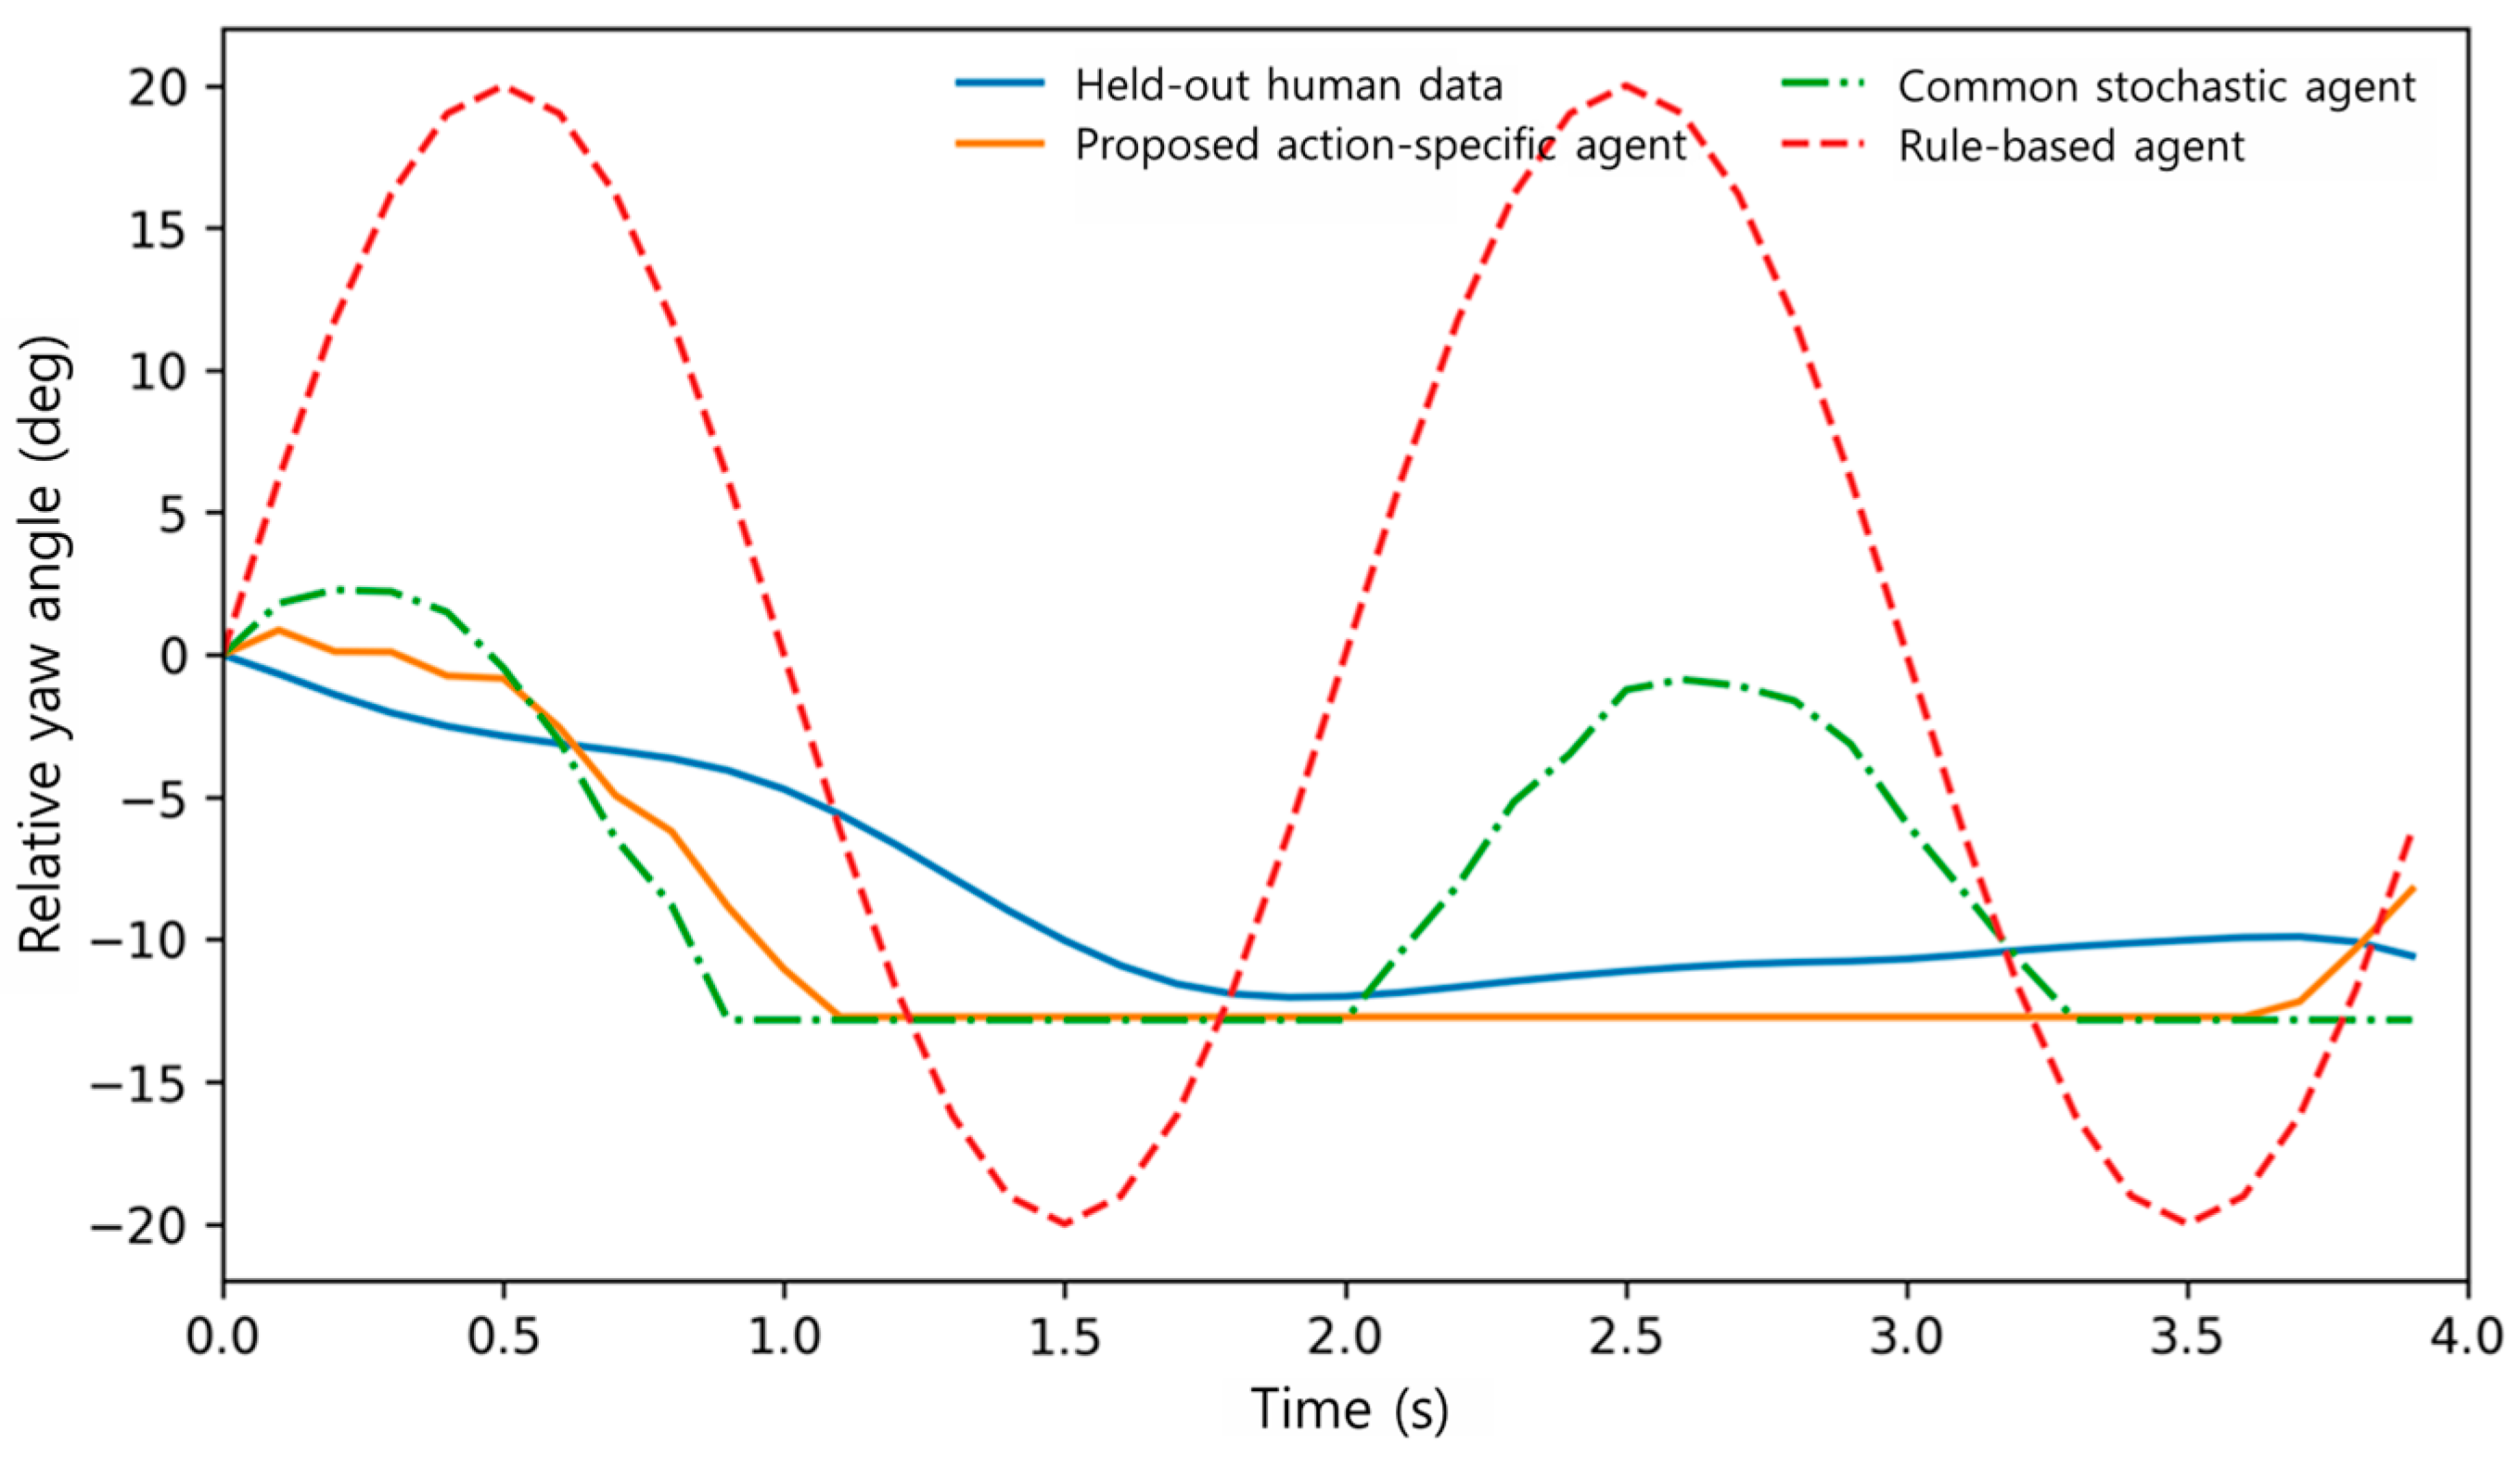
Figure 5 shows representative relative yaw trajectories from the held-out human data and the three agents under the stationary monitoring condition. The common stochastic agent introduces temporal variation but applies one pooled parameter profile to all actions, whereas the proposed action-specific agent uses profiles estimated separately for each action from the calibration data. The rule-based agent follows fixed scanning parameters.
The trajectories are presented to illustrate differences in temporal structure rather than point-by-point agreement or overall superiority. The rule-based agent follows a regular periodic pattern, whereas the common stochastic and proposed agents introduce temporal variation. Quantitative agreement with the held-out recordings is evaluated separately using the three metrics reported in Table 4.
Table 4 reports the participant-independent descriptive results obtained from the 20 LOSO folds. The proposed action-specific agent has a lower orientation-state proportion deviation than both comparison agents in each of the six actions. Its switching interval deviation is lower than that of the common stochastic agent in five of the six actions, equal in standing at the reported precision, and lower than that of the rule-based agent in five of the six actions.
Yaw-distribution similarity depended on the action and the agent being compared. The proposed agent showed higher yaw-distribution similarity than the common stochastic agent for standing, sitting, and conversing, whereas the rule-based agent had the highest participant-level mean. The relatively high yaw-distribution similarity of the rule-based agent does not imply closer temporal trajectory agreement, because this metric compares the marginal distribution of yaw angles rather than their temporal sequence. Fixed periodic scanning can match the yaw distribution under some action conditions even when its temporal persistence and orientation-state composition differ from the held-out recordings.
Table 5 reports the participant-level paired comparisons, including 95% confidence intervals for the paired differences, Holm-adjusted p-values, and effect sizes. The proposed agent had lower yaw-distribution similarity than the rule-based agent but higher similarity than the common stochastic agent. Its switching interval deviation and orientation-state proportion deviation were lower than those of both comparison agents. All six pairwise differences remained significant after Holm correction. These results indicate a metric-dependent trade-off. The rule-based agent better matches the marginal yaw distribution. The action-specific agent more closely reproduces switching persistence and orientation-state composition.
Table 6 reports the parameter-wise replacement results under the same LOSO validation procedure.
The parameter-wise replacement results indicate that scan amplitude, reorientation magnitude, and directional bias mainly affect yaw-distribution similarity, whereas the switching interval and orientation-state proportions primarily affect their corresponding temporal and compositional measures. The effect of directional bias is smaller than that of the scan amplitude and reorientation magnitude.

5.3. Limitations

Eye movements that occur without corresponding head movement are not represented by the model. The field-of-view rule was not validated as a measure of human gaze allocation or visual fixation.
The participant group and actions were selected to support simulation-oriented parameter extraction. The results should be interpreted as action-specific parameter profiles for virtual agent control rather than as population-level behavioral statistics. Additional participants, age groups, and task contexts would be required to generalize the extracted profiles beyond the experimental conditions used in this study.
The evaluation included a fixed rule-based agent and a common stochastic agent. These comparisons separate action-specific parameterization from fixed heuristic control and general stochastic variation, but they do not cover learning-based or hybrid orientation controllers. Future evaluation should examine additional agent control models and more complex multi-agent scenarios.
The simulation scenario also used a simplified environmental context. The points of interest were included as spatial objects whose detectability depended on the current field-of-view direction, but the model did not explicitly consider object saliency, occlusion, task priority, or interaction with other agents. Incorporating environmental context would allow the same parameterization method to support more detailed perception–action interactions.
The evaluation focused on agreement with measured head-orientation profiles and did not examine how update latency affects an observer’s interpretation of the virtual agent. Response timing can influence the perceived fluency and predictability of autonomous behavior [21], even when the generated motion follows an appropriate directional pattern. Future evaluation should examine controller timing together with observer-based assessments of behavioral naturalness.

6. Conclusions

This study derived action-specific head-orientation parameters from head-mounted IMU recordings and mapped them to FSM perception-control variables in a virtual human agent. Participant-independent LOSO validation showed that the action-specific agent produced lower switching interval and orientation-state proportion deviations than both comparison agents. Its yaw-distribution similarity was higher than that of the common stochastic agent but lower than that of the fixed rule-based agent. The parameter-wise replacement analysis showed that scan amplitude, reorientation magnitude, and directional bias mainly affected yaw-distribution similarity, whereas switching interval and orientation-state proportion had greater effects on their corresponding temporal and compositional measures. The main benefit of action-specific parameterization was observed in temporal persistence and orientation-state composition rather than in marginal yaw-distribution agreement.
The resulting parameter profiles provide reusable control values for FSM-based simulation without replaying individual recorded trajectories or requiring online model inference. They allow action-dependent head-orientation behavior to be incorporated while retaining explicit FSM control. Future work will examine environmental context, additional sensing modalities, and multi-agent interactions.

Funding

This research was supported by the Challengeable Future Defense Technology Research and Development Program (915160201) of Agency for Defense Development in 2026.

Institutional Review Board Statement

No formal institutional ethics committee review or exemption determination was sought prior to data collection, and no ethics approval or exemption reference number was issued. The study involved only non-invasive head motion recording from adult volunteers, collected no sensitive personal information or identifiable images, and posed minimal risk to the participants.

Informed Consent Statement

Verbal informed consent was obtained from all participants before data collection. This approach was used because the study involved non-invasive, minimal-risk head motion recording and no directly identifying or sensitive personal information was collected. The study purpose, procedures, voluntary nature of participation, right to discontinue participation, intended data use, and privacy protection were explained before participation. Written consent forms were not collected.

Data Availability Statement

The raw IMU recordings are not available for public release because the informed consent obtained from the participants did not include public sharing of participant-level motion recordings. Aggregated parameter values and summary results are provided within the article and Appendix A.

Conflicts of Interest

The author declares no conflicts of interest. The funder had no role in the design of the study; in the collection, analyses, or interpretation of data; in the writing of the manuscript; or in the decision to publish the results.

Appendix A. Reproducibility Details for IMU-Derived Head-Orientation Parameterization

This appendix summarizes implementation settings not repeated in the main text. It includes preprocessing and orientation-state identification settings, numerical definitions of extracted head-orientation parameters, simulation execution settings, and the sensitivity to preprocessing and orientation-state identification settings.

Appendix A.1. Preprocessing and Orientation-State Identification Settings

Orientation states were identified from the preprocessed yaw trajectory using sliding-window analysis of head-orientation dynamics. Within each window, absolute yaw angular velocity and yaw variance were computed to characterize orientation stability and abrupt head reorientation. Thresholds were defined using action-specific percentile criteria rather than fixed global values to reduce sensitivity to inter-participant variability, sensor noise, and differences in action-dependent motion intensity.
Prior to state identification, yaw angles were unwrapped and duplicated or invalid timestamp entries were removed, and each recording was interpolated to a uniform 10 Hz time grid. The median yaw during the initial 1 s was subtracted as the session-level reference orientation. Samples exceeding the 250 deg/s artifact threshold were removed and linearly interpolated. A second-order Butterworth low-pass filter was then applied using forward–backward zero-phase filtering with a nominal cutoff frequency of 2.0 Hz. Table A1 lists the numerical settings used for preprocessing and orientation-state identification.
Table A1. Numerical settings used for preprocessing and orientation-state identification.
SettingValueUse in This Study
Sliding window length1.5 sTemporal window for local state analysis
Window overlap50%Overlap between consecutive analysis windows
Lower velocity threshold30th percentile of absolute yaw rateUsed with yaw variance to detect steady-orientation
Upper velocity threshold80th percentile of absolute yaw rateUsed to detect rapid head turns
Lower variance threshold30th percentile of yaw varianceUsed with angular velocity to detect steady-orientation
Minimum extrema count for scanning2Required number of alternating local extrema within a window
Switching threshold15 degMinimum angular change for head-orientation switching
Artifact threshold250 deg/sUsed during preprocessing to remove transient artifacts
Resampling rate10 HzUniform time base for preprocessing and parameter extraction
A window was labeled as steady-orientation when both yaw variance and absolute yaw angular velocity were below the lower thresholds. A window was labeled as a rapid-turn when the peak absolute yaw angular velocity exceeded the upper velocity threshold. Windows that did not satisfy either condition but contained at least two alternating local extrema were labeled as scanning states. Windows that did not satisfy any of these criteria were temporarily classified as transitional. Because adjacent analysis windows overlap, sample-level labels were determined by majority voting among all windows containing the sample. Ties were resolved in the order of rapid-turn, scanning, steady-orientation, and transition. Transitional samples were then assigned to the nearest valid orientation state so that the final representation retained the three orientation states: steady-orientation, scanning, and rapid-turn. These criteria were applied independently within each action.

Appendix A.2. Definition of Extracted Head-Orientation Parameters

The head-orientation parameters used in the proposed agent were extracted from preprocessed yaw trajectories using deterministic signal-based rules. Each parameter was defined to correspond directly to a perception-control variable in the FSM-based virtual human agent. Table A2 lists the numerical definition and unit of each extracted parameter.
Table A2. Numerical definitions of extracted head-orientation parameters.
ParameterNumerical DefinitionUnit
Scan amplitudeMaximum yaw minus minimum yaw within a detected scanning episodedeg
Scan periodMean temporal interval between consecutive same-direction extremas
Directional biasMean yaw offset from the session-level reference orientation during scanningdeg
Head-orientation switching intervalElapsed time between consecutive significant yaw direction changess
Reorientation magnitudeYaw angle displacement associated with rapid-turn episodesdeg
Orientation-state proportionDuration ratio of each orientation state within a recording sessiondimensionless ratio
Scanning episodes were identified from windows labeled as scanning states. Local extrema were detected from the filtered yaw trajectory, and the temporal spacing between same-direction extrema was used to estimate the scan period. Directional bias was computed relative to the normalized forward-facing orientation of each recording session. Orientation-state proportions were calculated within each recording session by normalizing the duration of steady-orientation, scanning, and rapid-turn states by the total session duration. Orientation-state proportions are reported as dimensionless fractions, such as 0.52/0.34/0.14, rather than percentages.

Appendix A.3. Simulation Execution Settings

During simulation, head-orientation behavior was updated continuously within each FSM action state. At each simulation step, the active action state selected the corresponding action-specific parameter profile, and the active orientation state updated the agent’s yaw direction according to the extracted head-orientation parameters. Table A3 summarizes the settings used in the simulation comparison.
Table A3. Simulation execution and agent settings used in the evaluation.
SettingValueDescription
Simulation update rate10 HzFrequency of head-orientation updates
Simulation duration per run120 sDuration of each simulation run
Number of runs per action20Repeated runs used for evaluation
Number of points of interest6Spatial objects whose detectability depended on the current field-of-view direction
Proposed agent dwell time sourceEmpirical switching interval distributionUsed to determine orientation-state duration
Proposed agent scan amplitude sourceAction-specific empirical distributionUsed during scanning states
Proposed agent scan period sourceAction-specific empirical distributionUsed to set scanning oscillation timing
Proposed agent reorientation magnitude sourceAction-specific empirical distributionUsed during rapid-turn states
Proposed agent orientation-state proportion sourceAction-specific orientation-state proportionsUsed to determine relative occurrence of orientation states
Rule-based agent scan amplitude±20 degFixed scan range of the rule-based agent
Rule-based agent scan period2.0 sFixed sweep period of the rule-based agent
Rule-based agent reorientation probability0.05 per stepEvent probability for rapid-turn in the rule-based agent
Validation scheme20-fold leave-one-subject-outOne participant used for evaluation in each fold
Calibration participants per fold19Used to construct fold-specific parameter profiles
Held-out participants per fold1Used only as the held-out human reference
Proposed agent directional bias sourceAction-specific mean yaw offsetUsed to shift the scanning center
Common stochastic profile sourcePooled calibration data from all six actionsSame parameter profile applied to every action
The same simulation duration, update rate, and points of interest were used for all three agents. In each LOSO fold, the action-specific and common stochastic profiles were constructed from the 19 calibration participants. The proposed agent used separate parameter profiles for the six actions, including an action-specific directional bias. The common stochastic agent used one pooled profile for all actions, whereas the rule-based agent used fixed heuristic settings without IMU-derived parameters.
Given preprocessed head-orientation trajectories, the orientation-state identification process, parameter extraction, and FSM parameterization can be reproduced using the deterministic rules and simulation settings summarized above. The procedure requires no proprietary model, hidden learned representation, or end-to-end learning component.

Appendix A.4. Sensitivity to Preprocessing and Orientation-State Identification Settings

The nominal settings used in the main analysis were the 30th and 80th percentile thresholds, a 1.5 s analysis window, a 15° switching threshold, a 250 deg/s artifact threshold, and a 2.0 Hz low-pass filter cutoff. Sensitivity was evaluated by varying one setting at a time while keeping the remaining settings unchanged. The lower percentile was varied to the 25th and 35th percentiles, the upper percentile to the 75th and 85th percentiles, the window length to 1.0 and 2.0 s, the switching threshold to 10° and 20°, the artifact threshold to 200 and 300 deg/s, and the filter cutoff to 1.5 and 2.5 Hz.
For scan amplitude, scan period, switching interval, and reorientation magnitude, Table A4 reports the mean absolute percentage change across the six actions relative to the nominal setting. Directional bias is reported as the mean absolute change in degrees. For orientation-state proportions, the maximum absolute change among the three states is reported in percentage points.
Table A4. Sensitivity of the extracted action-specific profiles to variations in preprocessing and orientation-state identification settings.
Perturbed SettingScan Amplitude Change (%)Scan Period Change (%)Switching Interval Change (%)Reorientation Magnitude Change (%)Directional Bias Change (deg)Maximum Orientation-State Proportion Change (pp)
Lower percentile: 25th1.090.960.000.410.144.13
Lower percentile: 35th1.901.800.000.450.294.05
Upper percentile: 75th10.661.760.002.160.576.09
Upper percentile: 85th11.231.650.003.890.495.29
Window length: 1.0 s17.1111.770.003.250.5315.00
Window length: 2.0 s13.676.890.001.260.564.53
Switching threshold: 10°0.000.0011.510.000.000.00
Switching threshold: 20°0.000.007.430.000.000.00
Artifact threshold: 200°/s0.080.020.751.14<0.010.16
Artifact threshold: 300°/s<0.010.000.001.07<0.010.00
Filter cutoff: 1.5 Hz4.8212.502.532.100.408.39
Filter cutoff: 2.5 Hz1.7910.560.851.960.403.51
The changes in the lower percentile had relatively little effect on the extracted continuous parameters, whereas changes in the upper percentile mainly affected scan amplitude. Changes in the switching threshold primarily affected the switching interval, while variation in the artifact threshold had little effect on the extracted profiles.
Window length had a larger influence on the scan-related parameters, particularly at 1.0 s. The filter cutoff also affected the scan period more than the other continuous parameters. The nominal 1.5 s window and 2.0 Hz cutoff were retained as intermediate settings within the tested ranges, with the 1.5 s window providing sufficient temporal resolution for local state identification.

References

  1. Badler, N.I.; Phillips, C.B.; Webber, B.L. Simulating Humans: Computer Graphics Animation and Control; Oxford University Press: New York, NY, USA, 1993. [Google Scholar]
  2. Musse, S.R.; Cassol, V.J.; Thalmann, D. A History of Crowd Simulation: The Past, Evolution, and New Perspectives. Vis. Comput. 2021, 37, 3077–3092. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  3. Iovino, M.; Scukins, E.; Styrud, J.; Ögren, P.; Smith, C. A Survey of Behavior Trees in Robotics and AI. Robot. Auton. Syst. 2022, 154, 104096. [Google Scholar] [CrossRef] [Scilit]
  4. Bulling, A.; Blanke, U.; Schiele, B. A Tutorial on Human Activity Recognition Using Body-Worn Inertial Sensors. ACM Comput. Surv. 2014, 46, 33. [Google Scholar] [CrossRef] [Scilit]
  5. Madgwick, S.O.H.; Harrison, A.J.L.; Vaidyanathan, R. Estimation of IMU and MARG Orientation Using a Gradient Descent Algorithm. In Proceedings of the 2011 IEEE International Conference on Rehabilitation Robotics (ICORR), Zurich, Switzerland, 29 June–1 July 2011; pp. 1–7. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  6. Magnenat-Thalmann, N.; Thalmann, D. Virtual Humans: Thirty Years of Research, What Next? Vis. Comput. 2005, 21, 997–1015. [Google Scholar] [CrossRef] [Scilit]
  7. Zhang, Q.; Yao, J.; Yin, Q.; Zha, Y. Learning Behavior Trees for Autonomous Agents with Hybrid Constraints Evolution. Appl. Sci. 2018, 8, 1077. [Google Scholar] [CrossRef] [Scilit]
  8. Peng, X.B.; Abbeel, P.; Levine, S.; van de Panne, M. DeepMimic: Example-Guided Deep Reinforcement Learning of Physics-Based Character Skills. ACM Trans. Graph. 2018, 37, 143. [Google Scholar] [CrossRef] [Scilit]
  9. Ha, E.; Byeon, G.; Yu, S. Full-Body Motion Capture-Based Virtual Reality Multi-Remote Collaboration System. Appl. Sci. 2022, 12, 5862. [Google Scholar] [CrossRef] [Scilit]
  10. Fraser, A.; Hollett, R.; Speelman, C.; Rogers, S.L. Behavioural Realism and Its Impact on Virtual Reality Social Interactions Involving Self-Disclosure. Appl. Sci. 2025, 15, 2896. [Google Scholar] [CrossRef] [Scilit]
  11. Kok, M.; Hol, J.D.; Schön, T.B. Using Inertial Sensors for Position and Orientation Estimation. Found. Trends Signal Process. 2017, 11, 1–153. [Google Scholar] [CrossRef] [Scilit]
  12. Nweke, H.F.; Teh, Y.W.; Al-Garadi, M.A.; Alo, U.R. Deep Learning Algorithms for Human Activity Recognition Using Mobile and Wearable Sensor Networks: State of the Art and Research Challenges. Expert Syst. Appl. 2018, 105, 233–261. [Google Scholar] [CrossRef] [Scilit]
  13. Wang, J.; Chen, Y.; Hao, S.; Peng, X.; Hu, L. Deep Learning for Sensor-Based Activity Recognition: A Survey. Pattern Recognit. Lett. 2019, 119, 3–11. [Google Scholar] [CrossRef] [Scilit]
  14. Hammerla, N.Y.; Halloran, S.; Plötz, T. Deep, Convolutional, and Recurrent Models for Human Activity Recognition Using Wearables. In Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence (IJCAI-16), New York, NY, USA, 9–15 July 2016; pp. 1533–1540. [Google Scholar]
  15. Leelasawassuk, T.; Damen, D.; Mayol-Cuevas, W.W. Estimating Visual Attention from a Head Mounted IMU. In Proceedings of the 2015 ACM International Symposium on Wearable Computers, Osaka, Japan, 7–11 September 2015; pp. 147–150. [Google Scholar] [CrossRef] [Scilit]
  16. Bovo, R.; Giunchi, D.; Sidenmark, L.; Gellersen, H.; Costanza, E.; Heinis, T. Real-Time Head-Based Deep-Learning Model for Gaze Probability Regions in Collaborative VR. In Proceedings of the 2022 Symposium on Eye Tracking Research and Applications (ETRA ’22); ACM: New York, NY, USA, 2022; pp. 1–8. [Google Scholar] [CrossRef] [Scilit]
  17. Hu, Z.; Zhang, C.; Li, S.; Wang, G.; Manocha, D. SGaze: A Data-Driven Eye-Head Coordination Model for Realtime Gaze Prediction. IEEE Trans. Vis. Comput. Graph. 2019, 25, 2002–2010. [Google Scholar] [CrossRef] [PubMed]
  18. Rubow, C.; Tsai, C.-H.; Brewer, E.; Mattson, C.; Brown, D.S.; Zhang, H. A Dataset of Paired Head and Eye Movements during Visual Tasks in Virtual Environments. Sci. Data 2024, 11, 1328. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  19. Hu, J.; Sidenmark, L.; Lee, H.S.; Gellersen, H. The Eye–Head Mover Spectrum: Modelling Individual and Population Head Movement Tendencies in Virtual Reality. In Proceedings of the 2026 CHI Conference on Human Factors in Computing Systems (CHI ’26); ACM: New York, NY, USA, 2026; pp. 1–18. [Google Scholar] [CrossRef] [Scilit]
  20. Kokkinara, E.; Oyekoya, O.; Steed, A. Modelling Selective Visual Attention for Autonomous Virtual Characters. Comput. Anim. Virtual Worlds 2011, 22, 361–369. [Google Scholar] [CrossRef] [Scilit]
  21. Bo, V.; Garrell, A.; Sanfeliu, A. Fast or Accurate? How Intention-Recognition Models Shape Human Perception of a Mobile Robot. In Companion Proceedings of the 21st ACM/IEEE International Conference on Human-Robot Interaction (HRI Companion ’26), Edinburgh, Scotland, UK, 16–19 March 2026; ACM: New York, NY, USA, 2026; pp. 502–506. [Google Scholar] [CrossRef] [Scilit]
Figure 1. Overall procedure of the proposed IMU-derived head-orientation parameterization method.
Applsci 16 08728 g001
Figure 2. Representative raw and smoothed yaw trajectories after preprocessing.
Applsci 16 08728 g002
Figure 3. Example of head-orientation state segmentation based on yaw angle dynamics.
Applsci 16 08728 g003
Figure 4. Representative stationary monitoring segments concatenated for visualization, with derived orientation states.
Applsci 16 08728 g004
Figure 5. Representative relative yaw trajectories from held-out human data and the three simulation agents under the stationary monitoring condition.
Applsci 16 08728 g005
Table 1. Comparison of representative research directions and the proposed method.
Research DirectionTypical OutputLimitation for This Study
Rule-based virtual agentsStates, rules, behavior treesPerception parameters are manually tuned
IMU-based activity recognitionActivity labelsLabels do not provide control parameters
Motion capture virtual charactersReproduced motionFull-body motion focus, limited FSM mapping
Attention/gaze-based agentsGaze or attention rulesOften not derived from wearable head-orientation data
Proposed methodFSM control parametersRequires action-specific IMU recordings
Table 2. Mapping between extracted head-orientation parameters and FSM perception-control variables.
ParameterDescriptionRole in Virtual Human Agent
Scan amplitudeAngular range of yaw during scanning behaviorControls horizontal head sweep angle
Scan periodTemporal cycle of oscillatory head movementDetermines scanning frequency
Directional biasAsymmetry of scanning toward left or rightIntroduces preference in perception direction
Head-orientation switching intervalTime between consecutive significant head orientation changesGoverns dwell time of orientation states
Reorientation magnitudeAngular change during rapid head turnsControls angular displacement during rapid turns
Orientation-state proportionRelative duration of the three orientation statesDetermines orientation-state composition
Table 3. Action-specific head-orientation parameter profiles extracted from IMU data.
ActionScan Amplitude (deg)Scan Period (s)Directional Bias (deg)Switching Interval (s)Reorientation Magnitude (deg)Steady-Orientation/Scanning/Rapid-Turn
Standing18.2 ± 4.12.4 ± 0.50.5 ± 2.53.1 ± 0.821.5 ± 5.20.52/0.34/0.14
Walking14.8 ± 3.71.9 ± 0.40.5 ± 1.32.2 ± 0.624.7 ± 6.00.36/0.46/0.18
Running11.3 ± 3.21.6 ± 0.3−0.6 ± 1.51.8 ± 0.528.4 ± 6.80.28/0.49/0.23
Stationary monitoring25.7 ± 5.82.8 ± 0.6−2.5 ± 7.02.5 ± 0.731.2 ± 7.10.31/0.50/0.19
Sitting21.4 ± 4.92.6 ± 0.62.4 ± 2.73.6 ± 0.918.8 ± 4.70.64/0.24/0.12
Conversing16.9 ± 4.42.1 ± 0.5−2.7 ± 10.23.4 ± 0.819.6 ± 5.00.61/0.25/0.14
Table 4. Participant-independent action-level comparison among the rule-based, common stochastic, and proposed action-specific agents.
ActionAgentYaw-Distribution SimilaritySwitching Interval DeviationOrientation-State Proportion Deviation
StandingRule-based0.4250.3410.443
Common stochastic0.3050.2450.114
Proposed action-specific0.3640.2450.106
WalkingRule-based0.2631.0520.363
Common stochastic0.2231.4560.150
Proposed action-specific0.1981.0830.130
RunningRule-based0.1760.1110.347
Common stochastic0.1840.5290.190
Proposed action-specific0.1270.0520.157
Stationary monitoringRule-based0.5140.2610.334
Common stochastic0.4020.3210.157
Proposed action-specific0.3900.2480.123
SittingRule-based0.3560.4210.507
Common stochastic0.3130.2470.140
Proposed action-specific0.3810.2040.096
ConversingRule-based0.4670.3800.503
Common stochastic0.3720.2170.130
Proposed action-specific0.4110.1960.085
Participant-level mean ± SDRule-based0.367 ± 0.0360.428 ± 0.4280.416 ± 0.041
Common stochastic0.300 ± 0.0160.503 ± 0.6490.147 ± 0.019
Proposed action-specific0.312 ± 0.0240.338 ± 0.4890.116 ± 0.022
Table 5. Participant-level pairwise comparisons under leave-one-subject-out validation.
MetricComparatorProposed Mean ± SDComparator Mean ± SDPaired Difference
[95% CI]
Holm-Adjusted p Effect Size
Yaw-distribution similarityRule-based0.312 ± 0.0240.367 ± 0.036−0.055 [−0.075, −0.035]<0.001 r r b = 0.700
Common stochastic0.312 ± 0.0240.300 ± 0.0160.012 [0.004, 0.020]0.006 d z = 0.690
Head-orientation switching interval deviationRule-based0.338 ± 0.4890.428 ± 0.4280.090 [0.042, 0.137]0.002 d z = 0.884
Common stochastic0.338 ± 0.4890.503 ± 0.6490.165 [0.083, 0.247]<0.001 r r b = 0.900
Orientation-state proportion deviationRule-based0.116 ± 0.0220.416 ± 0.0410.300 [0.280, 0.319]<0.001 d z = 7.118
Common stochastic0.116 ± 0.0220.147 ± 0.0190.030 [0.021, 0.040]<0.001 d z = 1.543
Table 6. Parameter-wise replacement results under leave-one-subject-out validation.
Action-Specific Parameter Replaced by the Corresponding Common Stochastic Profile ParameterYaw-Distribution SimilaritySwitching Interval DeviationOrientation-State Proportion Deviation
None: full action-specific agent0.3120.3380.116
Scan amplitude0.3080.3380.116
Scan period0.3110.3380.116
Directional bias0.3090.3380.116
Switching interval0.3150.4970.119
Reorientation magnitude0.3050.3380.116
Orientation-state proportion0.3070.3390.146
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content.