1. Introduction
The model-order-reduction (MOR) problem for linear time-invariant (LTI) dynamical systems continues to play a foundational role in numerical simulation, optimization, identification, and control design when the state dimension increases due to spatial discretization or due to interconnection of multiple subsystems. Recent surveys indicate a general trend in MOR from the objective of good approximation toward structured approximation, meaning that the reduced model is required to preserve physical–mathematical invariants (e.g., stability, passivity, and energy dissipation) in order to avoid qualitative mismatch in closed-loop operation or in extrapolation beyond the training-data regime [
1,
2].
Among structural frameworks, port-Hamiltonian (pH) representations and dissipative Hamiltonian variants are often used to encode energy constraints and passivity directly. Studies on identification and data fitting in pH form from frequency responses and emphasize that even at the stage of constructing the full-order model, passivity preservation and order minimization constitute necessary conditions to ensure usability in inversion or system reversal [
3]. On that basis, surveys on structure-preserving MOR for interconnected pH systems, including nonlinear cases, have systematized projection and interpolation strategies that maintain energy constraints and have made explicit the difficulties that arise when additional frequency-domain conditions or parameter constraints are introduced [
4]. Recent data-driven approaches combining the Loewner framework for pH systems and network systems enable constructing reduced models directly from data, retaining pH properties to a certain extent when the projection operators and interpolation constraints are designed appropriately [
5]. Studies on structure-preserving discretization and MOR for boundary-controlled pH systems have shown that passivity preservation must be ensured throughout the chain: discretization → frequency-domain interpolation → physically meaningful projection construction [
6]. At a more general level, monograph chapters on reduction for descriptor pH-DAE systems have clarified the role of structured interpolation and the handling of algebraic constraints to avoid spurious dynamics [
7]. To reduce optimization costs in structured MOR algorithms, adaptive sampling strategies for pH systems demonstrate clear effectiveness when the number of subproblem solves is controlled by the fitting error [
8].
In many circuit–mechanical–electrical applications, model data may appear in descriptor form and require a reducer that is not only passive but also structure-compatible with algebraic constraints. In that direction, optimization-based MOR for port-Hamiltonian descriptor systems systematizes a transfer-function fitting procedure under pH constraints imposed on the reduced model, limiting the risk of passivity loss induced by purely projection-based reduction [
9]. Within the same viewpoint, structured optimization-based MOR (SOBMOR) provides an approach that fits the transfer function while locking pH/structured properties, which is suitable when preserving system properties is prioritized over optimizing a single error norm [
10]. From a broader perspective, dissipativity-preserving methods based on moment matching extend the scope of property preservation to general dissipative systems, in which stability and dissipation inequalities are maintained regardless of interpolation-point placement [
11]. Beyond moment matching, a spectral-factorization-based direction for passivity preservation has shown that passive reduced models can be designed without explicit pH constraints by exploiting the positive-real structure of the transfer function [
12]. For symmetric second-order systems, positive-real balancing enables order reduction while retaining the physical structure of the mechanical system (mass–damping–stiffness), which avoids non-physical modes and supports post-reduction physical interpretation [
13].
When the objective includes preserving subtler frequency-domain properties, especially those related to system zeros, existing results remain scattered across problem classes. For pH systems, interval-limited balanced truncation has been proposed to reduce order over a frequency band or time window of interest while maintaining structure [
14]. The guarantees primarily focus on passivity and stability rather than directly targeting minimum-phase preservation. On the quantitative side, error-bounding results and controller reduction for pH systems based on balancing show how to exploit degrees of freedom in weighting to support controller synthesis under error constraints [
15]. Studies on a posteriori error bounds for pH systems continue to improve the ability to assess reduced-model reliability through auxiliary problems for the error system [
16]. For positive-real systems, mixed-Gramian balanced truncation (MGBT) with error bounds reduces computational load relative to classical PRBT and provides controlled error assessments [
17]. Mixed positive-bounded balanced truncation targets simultaneous preservation of positive realness and bounded realness, which is suitable when a system is passive and subject to gain constraints [
18]. Phase-angle balanced truncation within conic positive real frameworks incorporates transfer-function phase information into the reduction criterion, improving phase matching relative to purely energy-based criteria [
19]. From the dissipation-inequality viewpoint, extended balancing for LTI systems provides a unified LMI characterization and suggests a priori error bounds and links to structure-preserving reduction for the pH subclass [
20]. These works mainly address passivity, dissipativity, sector conditions, and phase matching in an approximate sense. Minimum-phase preservation, which is directly tied to zero structure and stable invertibility, is rarely treated as a central constraint of balanced-truncation algorithms.
From a practical perspective, preserving the minimum-phase property during model reduction is important for filter design, signal processing, and control applications. A minimum-phase system admits a stable and causal inverse; hence, a reduced model retaining this property can be used reliably in inverse filtering, equalization, signal reconstruction, and controller synthesis without introducing unstable inverse dynamics [
21,
22]. Moreover, among causal systems having the same magnitude response, a minimum-phase realization has the smallest group delay and the most front-loaded impulse-response energy, which supports reliable phase behavior and favorable transient characteristics after reduction [
21].
Beyond property constraints, a practical challenge is the selection of the order
r in balanced truncation when the system is large and/or only a finite operating domain is of interest. Frequency-limited balancing techniques have been developed with low-rank approximations to address large-scale frequency-limited Gramian problems [
23]. Time-limited balancing has formed a separate methodological branch, in which Gramian computation and error bounds are adapted to a time window of interest [
24]. Recent results on numerical computation and output bounds for discrete-time systems increase robustness when applied in simulation and digital control [
25]. Applications in data assimilation show that time-limited balanced truncation can serve as an effective preprocessing tool to reduce inference costs when accuracy is required only over an observation interval [
26]. For second-order systems, frequency–time-limited balancing has been extended in a structure-preserving direction to avoid breaking the physical description of the system [
27]. Recent short contributions on low-rank approximations for frequency-limited Gramians of discrete-time systems further strengthen the computational basis for variants of balancing with a domain of interest [
28]. Even when Hankel/Gramian-type error bounds are available, the practice of choosing r often relies on heuristic thresholds, particularly when trade-offs are required among norm errors, transient responses, and phase deviations in the frequency domain.
A related line focuses on frequency-domain approximation criteria and weighted
norm settings. Work on frequency-weighted
-optimal MOR based on oblique projection shows that priority can be concentrated on important frequency bands through weighting, rather than relying only on full-band controllability–observability balancing [
29]. In a time-window-compatible direction, modeling in a time-limited
setting under relative error has been proposed to reduce bias when the signal amplitude varies strongly over time [
30]. The
relative error setting in Systems & Control Letters provides an additional view on how to pose approximation problems so that the acceptable error level is reflected on the system’s scale [
31]. Unstable stochastic systems impose additional constraints on Gramians and indicate the need to screen or preprocess system properties before applying standard balancing techniques [
32]. These results suggest that a controlled reduction workflow must manage baseline properties (stability, minimality, and structure) and integrate multi-domain evaluation criteria (time and frequency) to select
r consistently.
For order selection, automated schemes are beginning to appear, yet they often optimize a single metric. Energy-based order selection and scale homogenization in parameter–state spaces through empirical cross Gramians and symmetrizers have been proposed as a mechanism for automatic thresholding in identification and parameterization [
33]. In non-intrusive ROM contexts, a Pareto criterion between error and model complexity is used to select models on the Pareto frontier, emphasizing the multi-objective nature of the problem [
34]. Existing approaches typically emphasize structure (pH and dissipativity) without directly constraining minimum-phase properties, or they emphasize a single evaluation domain (e.g.,
or time-limited only) without providing a quantitative scoring mechanism that consistently aggregates time-response errors, magnitude–phase deviations over frequency, and characteristic system indices.
From these observations, this study develops a theoretical framework and mathematical arguments for Gramian-based balanced truncation under system-property preservation constraints. At a minimum, the framework preserves stability and is further extended to incorporate minimum-phase preservation. The resulting method is referred to as the MPPBT algorithm. In addition, a quantitative scoring procedure is developed to determine the optimal reduced order r.
The proposed method follows a controlled reduction workflow. First, the original system is screened to verify the baseline properties of stability, minimality, and minimum-phase behavior. Next, controllability and observability Gramians are used to quantify state importance. The system is then transformed into balanced coordinates, in which the states are ordered according to their contributions, allowing for low-importance states to be truncated to construct a reduced-order model.
Theoretical analysis establishes conditions under which the reduced model preserves stability. Moreover, when the MPPBT singular values associated with the truncated states are sufficiently small, the reduced model can also retain the minimum-phase property.
To avoid heuristic order selection, the study introduces a multi-domain evaluation framework consisting of norm errors, time-domain response indices, frequency-domain magnitude and phase deviations, and characteristic system indices. These criteria are normalized to a common scale and combined with the model-order measure to form a trade-off score. The resulting aggregate criterion provides a Pareto-based interpretation of the optimal order-selection problem. The effectiveness of MPPBT in preserving stability and minimum-phase properties is demonstrated using a fourth-order Butterworth low-pass filter derived from a one-plus-alpha filter structure, as reported in [
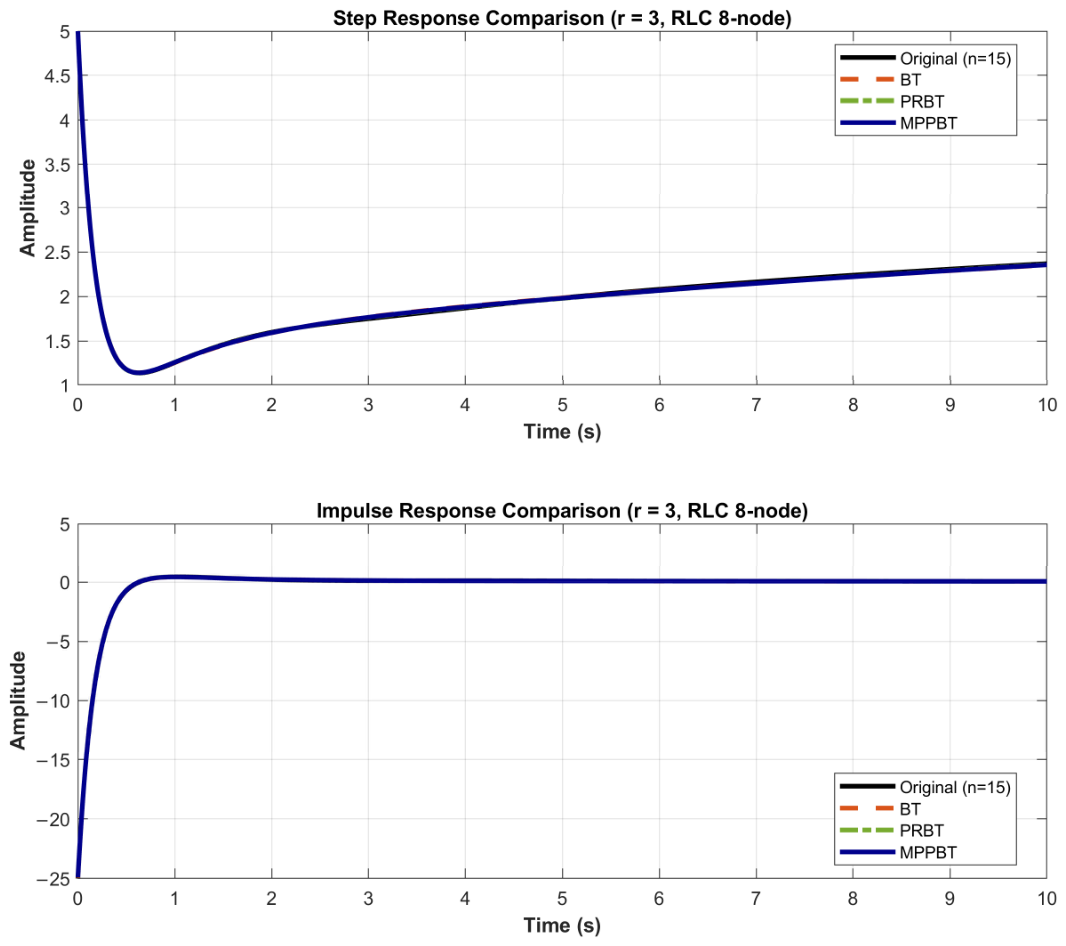
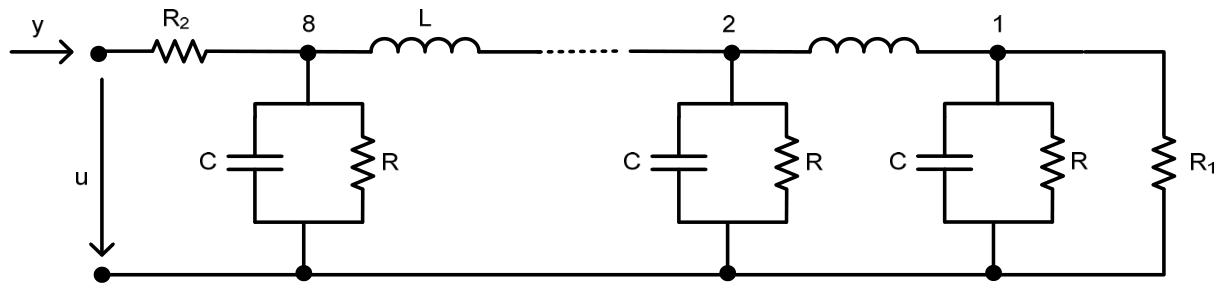
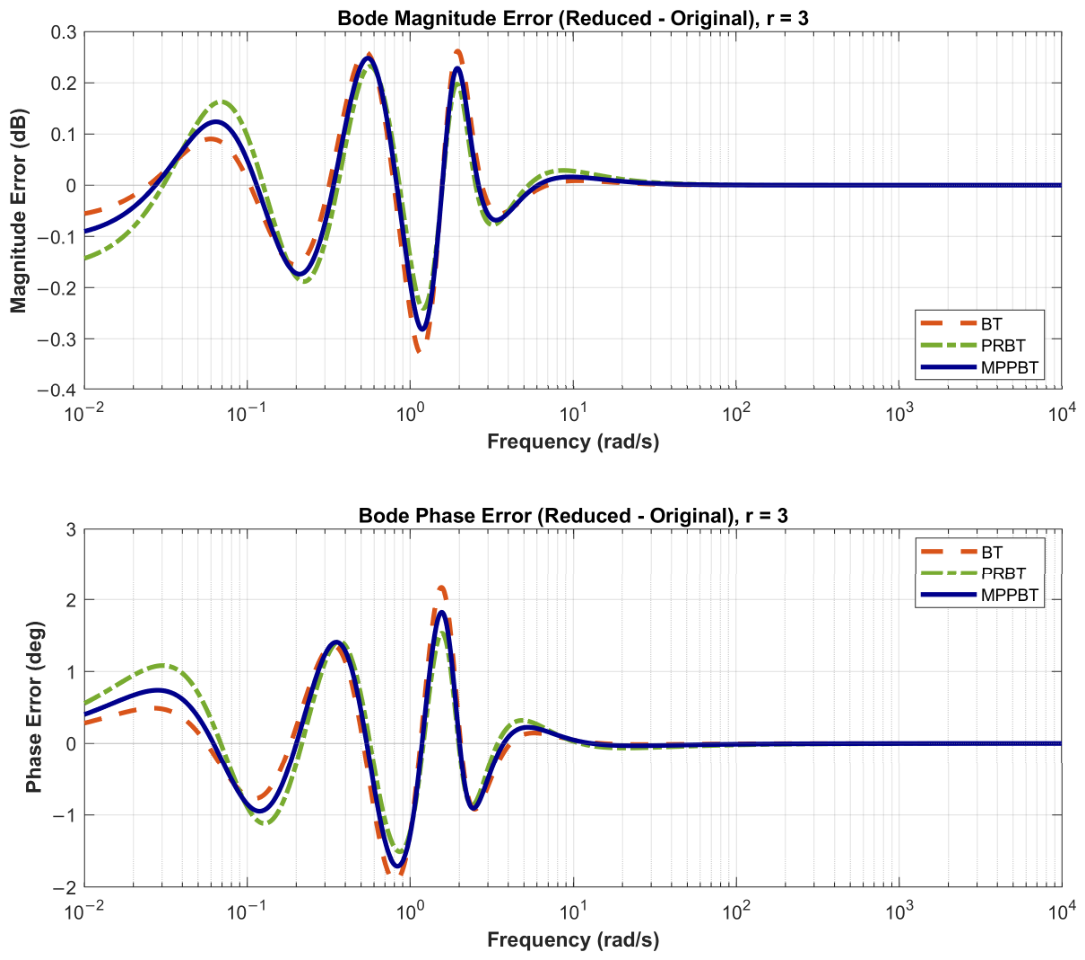
35]. The framework is further validated on a 15th-order passive RLC ladder circuit, where MPPBT is compared against classical BT and PRBT.
2. Mathematical Framework of Minimum Phase Preserving Balanced Truncation (MPPBT)
Definition 1. Given matrices , consider the (square) LTI system with : and the transfer function . The system is called MPPBT-admissible if: (i) is Hurwitz: ; (ii) is controllable and is observable; (iii) is nonsingular (equivalently ); (iv) is minimum phase: it has no RHP zeros, i.e., there is no with such that (for square full-normal-rank , equivalently for ) [12,36,37]. Definition 2. Define two linear operators
. The MPPBT controllability Gramian is the (unique) SPD solution of the Lyapunov equation in (1). From , define and ; define . The MPPBT observability Gramian is defined as the minimal (stabilizing) SPD solution of the Riccati equation in (2): [12,36,37]. The existence and uniqueness of these Gramians, together with the square-root factorizations and singular value decomposition used in Theorem 1, are established in Appendix A (Lemmas A1–A3). Theorem 1. Define
, . For , , , , the transformed Gramians satisfy and [37,38]. Proof of Theorem 1. since . Next, with , hence . Similarly, with , hence .
Lemma 1. In balanced coordinates, introduce the state partition and induced matrix blocks as follows (3) [37]: Moreover, partition
, where
,
. The order-
model in balanced coordinates is
. Define the projection matrices
,
; then the reduced realization is (4) [
37]:
is an order-
realization of
. Moreover, the sub-Gramians of the retained part satisfy
Proof of Lemma 1. The definition of implies that realizes and that the retained sub-Gramians satisfy , by construction of balanced coordinates.
Theorem 2. For an MPPBT-admissible system and the partition in (3), the matrix is Hurwitz; hence is stable [37]. Proof of Theorem 2. In balanced coordinates, the controllability Gramian equation reads . Taking the block gives . Let and be a left eigenvector, . Premultiplying/postmultiplying by yields . If , then , contradicting controllability of (Hautus). Thus for all , so is Hurwitz.
Theorem 3. Assume is minimum phase. If there exists such that , where , then is also minimum phase [36]. Proof of Theorem 3. For , . If , then is invertible for all (Neumann series), and since is invertible there, on .
Theorem 4. For the relative error operator , define the scalar function and accumulated factor as (5). Assume for all , then [36]. The following theorem bounds the -norm bound of the relative error. Assume for all , then
Proof of Theorem 4. In the BST relative-error construction, truncating each balanced component yields a stable perturbation factor , satisfying .
Therefore, the accumulated relative error resulting from truncating the states is bounded by the product of the individual perturbation factors. By the submultiplicativity of the norm and the triangle inequality, we obtain
Since , the right-hand side of (6) is equal to . Hence, , which proves the result. □
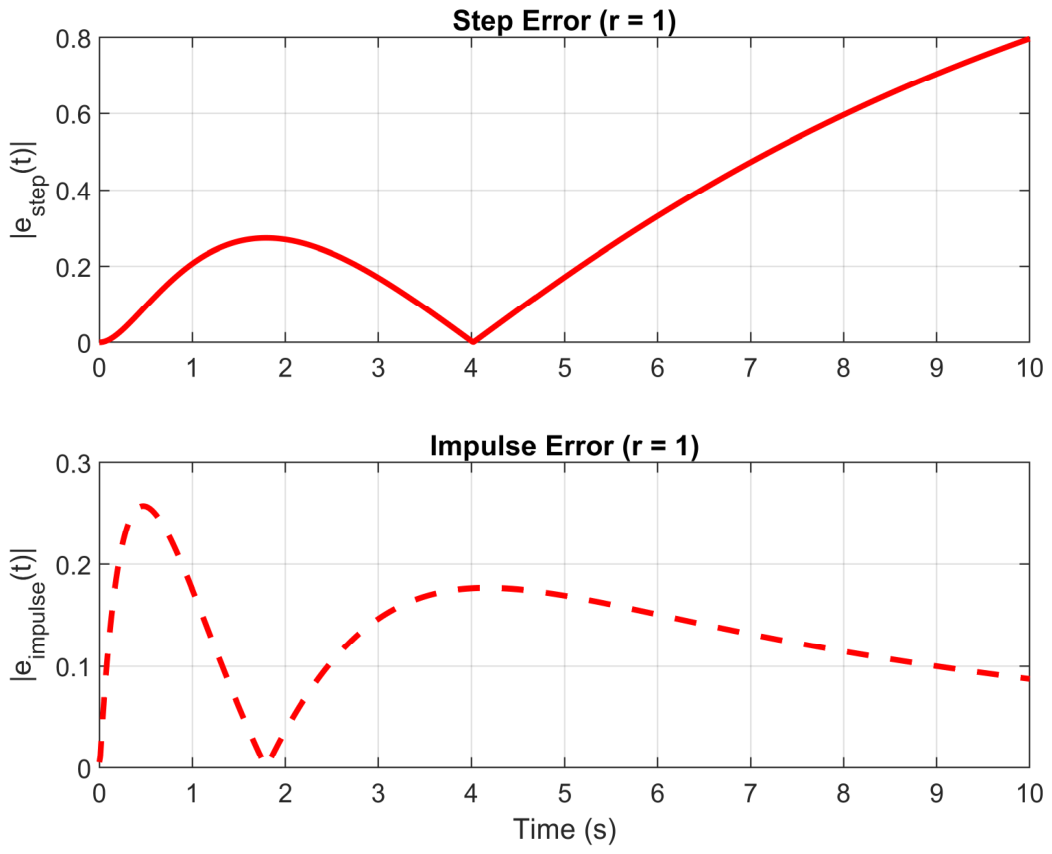
Corollary 1. Given , if there exists such that , then . For each , consider and . Define norm errors as (7); for step-response errors, define the step error signal as (8); and for , define the time-domain criteria by (9) [1,2,36]: For impulse-response errors, define the impulse error signal as (10) [
1,
2]:
Define
analogously by replacing
with
in (9). For frequency-domain errors (for a chosen SISO channel or applied entrywise), use the magnitude/phase decomposition in (11) [
2,
29]:
with
and
(unwrap on
), we define (12) [
2,
29]:
For reduced-model properties, we have (13) [
2]:
which are the DC gain and phase margin of the order-
model, respectively. Collect them into the vector
.
Lemma 2. Define , , and pick a small . The min–max normalized criterion is defined by (14). Then for all and all .
Then for all and all , .
Proof of Lemma 2. By definition, . Also and , hence . □
Definition 3. Choose an index subset
. Choose weights , with and . The composite error index is defined by (15). From Lemma 2 and , it follows that , where we define , . The order-complexity index is defined by (16). Then and is nondecreasing in . With , the MPPBT composite score is defined by (17). Hence . Cases: (error only), (order only), (trade-off).
Lemma 3. For fixed , is affine in on , as in (18). If and , then for all .
Proof of Lemma 3. The equation in (18) is a rearrangement of (17). If , then by (16) . Combining with and multiplying each inequality by nonnegative coefficients , , then summing yields the claim.
Theorem 5. For each , the minimization over attains at least one minimizer (19): Proof of Theorem 5. Since is finite, the set is a finite nonempty subset of . Therefore, it has a minimum, which proves (19).
Corollary 2. Define the bi-objective mapping by . For , every minimizer of (19) is Pareto-nondominated for the bi-objective problem i.e., there is no such that , , with at least one strict inequality. Conversely, every supported Pareto-nondominated point on the convex hull of is a minimizer of for some .
Proof of Corollary 2. Let , and suppose is optimal for . If there existed with and and at least one strict inequality, then by (17) with positive weights , , contradicting optimality. Hence is nondominated. For the converse, a supported nondominated point admits a supporting hyperplane with some weight vector ; setting yields a weighted-sum scalarization equivalent to minimizing , hence the point is optimal for some . .
Algorithm 1 summarizes the Minimum-Phase Preserving Balanced Truncation (MPPBT) workflow: it computes MPPBT-type Gramian factors via Lyapunov–Riccati solvers, constructs the MPPBT balancing transformation from the SVD of
, and generates reduced models
for
. Each candidate order is then evaluated using a unified multi-domain metric suite and selected by a min–max normalized composite score that trades accuracy against model complexity while enforcing stability and minimum-phase feasibility when required.
| Algorithm 1. Pseudocode of the Minimum-Phase Preserving Balanced Truncation (MPPBT) algorithm |
Input: (num,den), opts=(solver,ε), grids (t,w), selected criteria J_sel, weights (w_err,β)
1 sys←ss(tf(num,den)); (A,B,C,D)←(sys.A,sys.B,sys.C,sys.D); if cols(B)<rows(C) then (A,B,C,D)←(AT,CT,BT,DT)
2 R←lyap_factor(A,B); Bw←B·DT+R(RTCT); ←(rank(D) low or ||D|| small)? εI: R-from-qr(DT)
3 ←A−Bw((T)\C); ←Bw/; ←\C; L←riccati_factor(,,,opts.solver)
4 [U,Σ,V]←svd(LTR); T←R V Σ^{-1/2}; Tinv←Σ^{1/2}\(UTLT)
5 Precompute full responses of G(A,B,C,D): step/impulse on t, bode on w
6 For r=n−1…1: Vr←T(:,1:r); Wr←(Tinv(1:r,:))T; sysr←ss(WrTAVr,WrTB,CVr,D); compute φ(r) (all criteria)
7 Normalize: ϕ_j(r)=(φ_j(r)−min_r φ_j)/max(max_r φ_j−min_r φ_j,ε)
8 S_β(r)=(1−β)·
Σ
_{j∈J_sel} w_err(j)ϕ_j(r) + β·(r−r_min)/max(r_max−r_min,ε)
9 r*←argmin_r S_β(r); r*_SM←argmin_{r: stable∧minphase} S_β(r) (if any)
Output: HSV=diag(
Σ
), φ(r), S_β(r), r*, r*_SM |
4. Conclusions
This study presents a model-order-reduction framework for linear systems with minimum-phase behavior with emphasis on a Riccati–Lyapunov-type pair of Gramians and the MPPBT balancing transformation. The theoretical part establishes MPPBT-admissible conditions that guarantee the existence of a unique pair of positive definite Gramians and and sets up a balancing transformation so that the two Gramians coincide in the new coordinates and are associated with a sequence of singular values, , that quantify controllability–observability energy. On this basis a relative error bound in the norm is expressed through the function , which provides a direct link between the magnitude of and the quality of the reduced model in the minimum-phase setting.
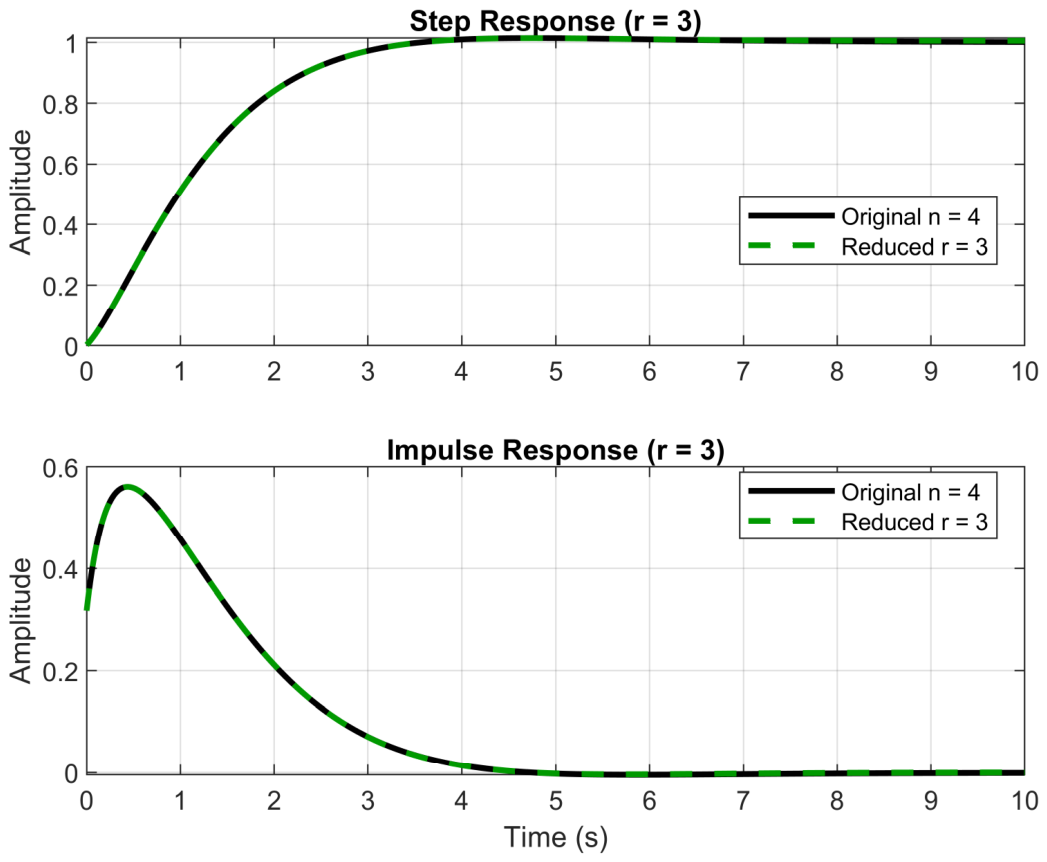
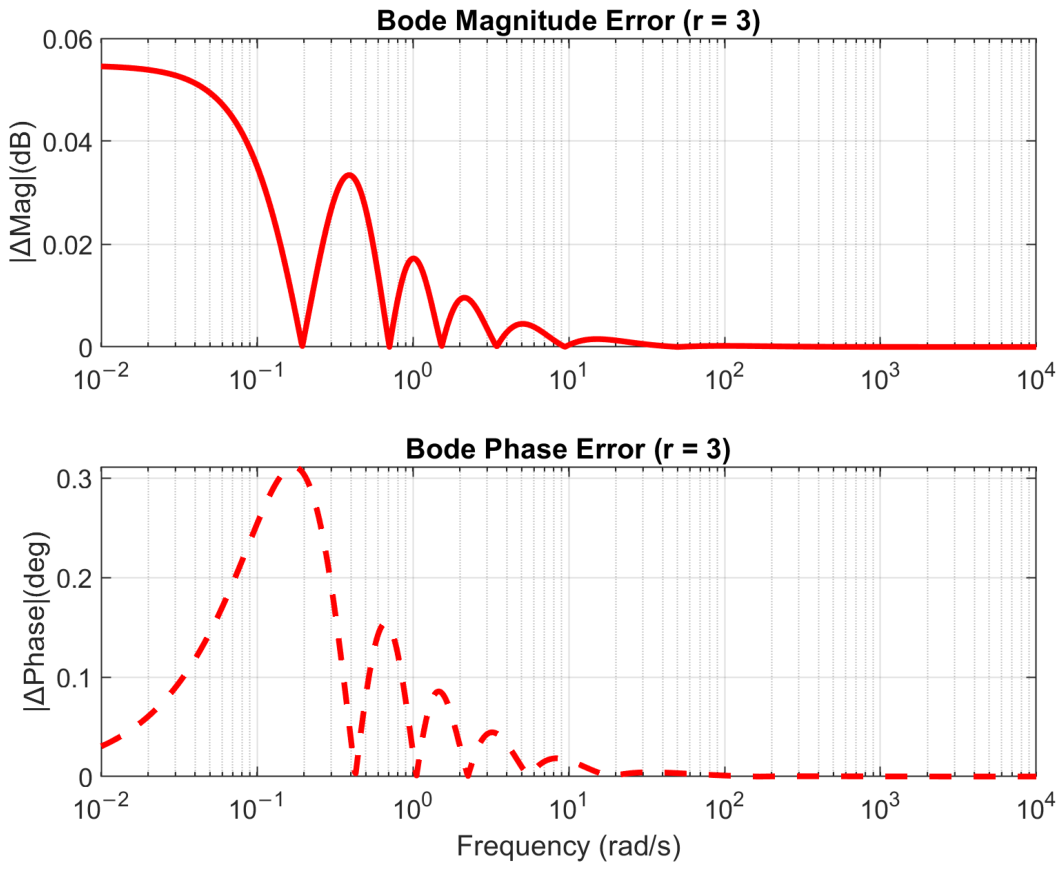
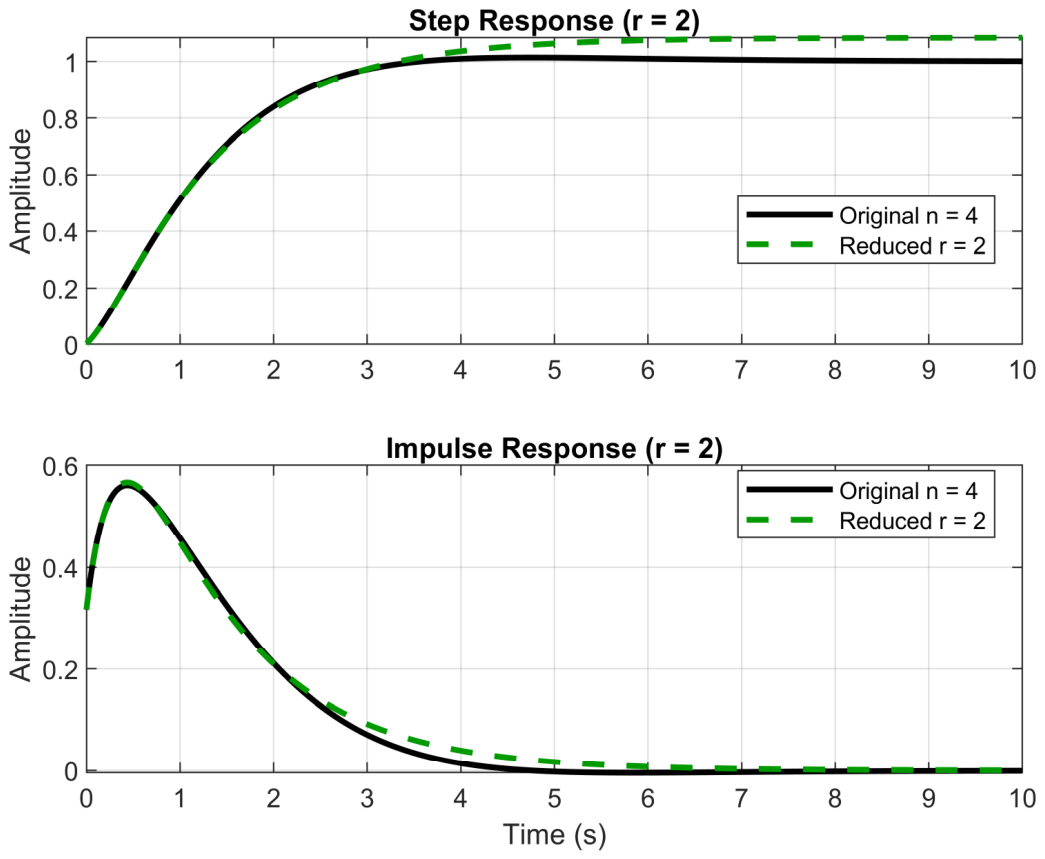
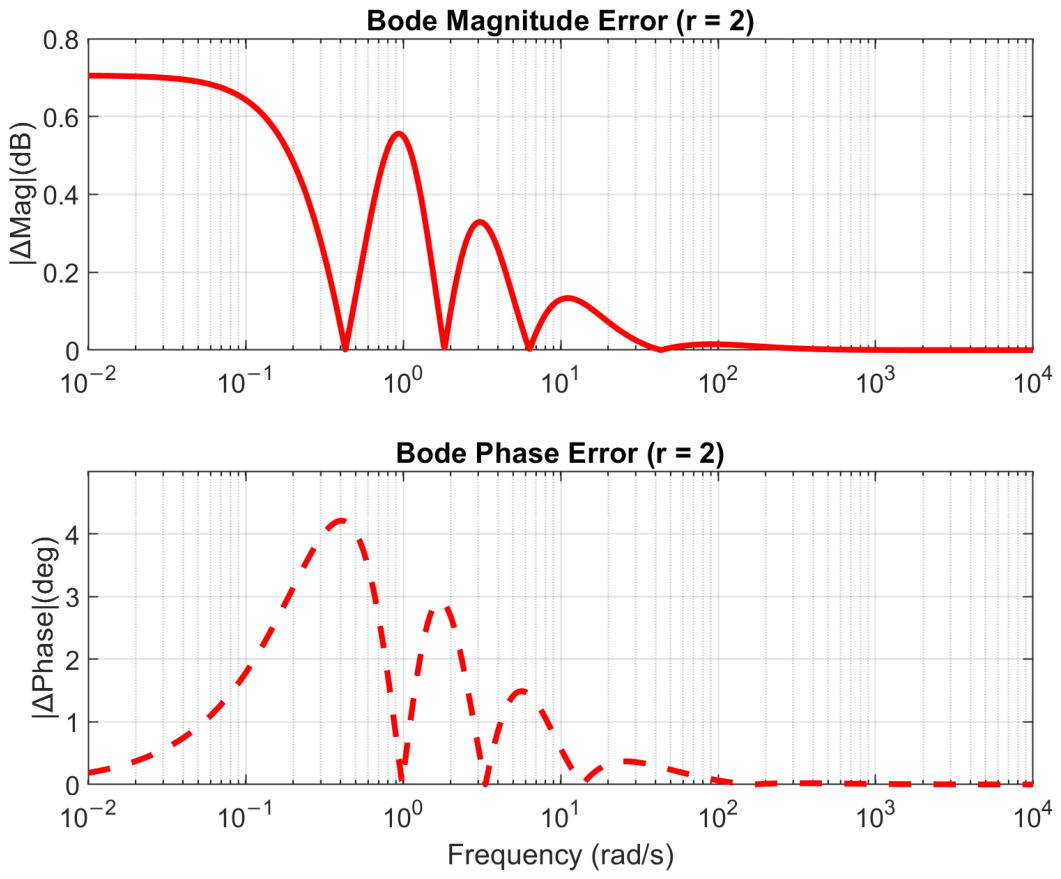
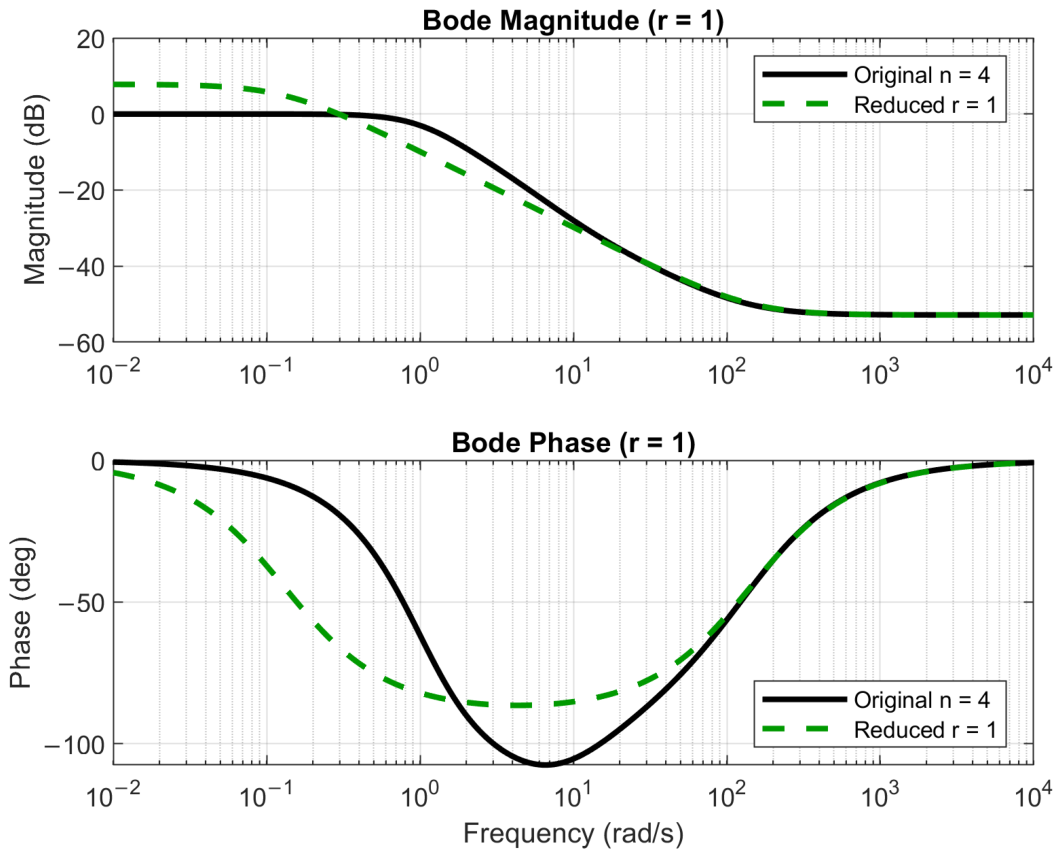
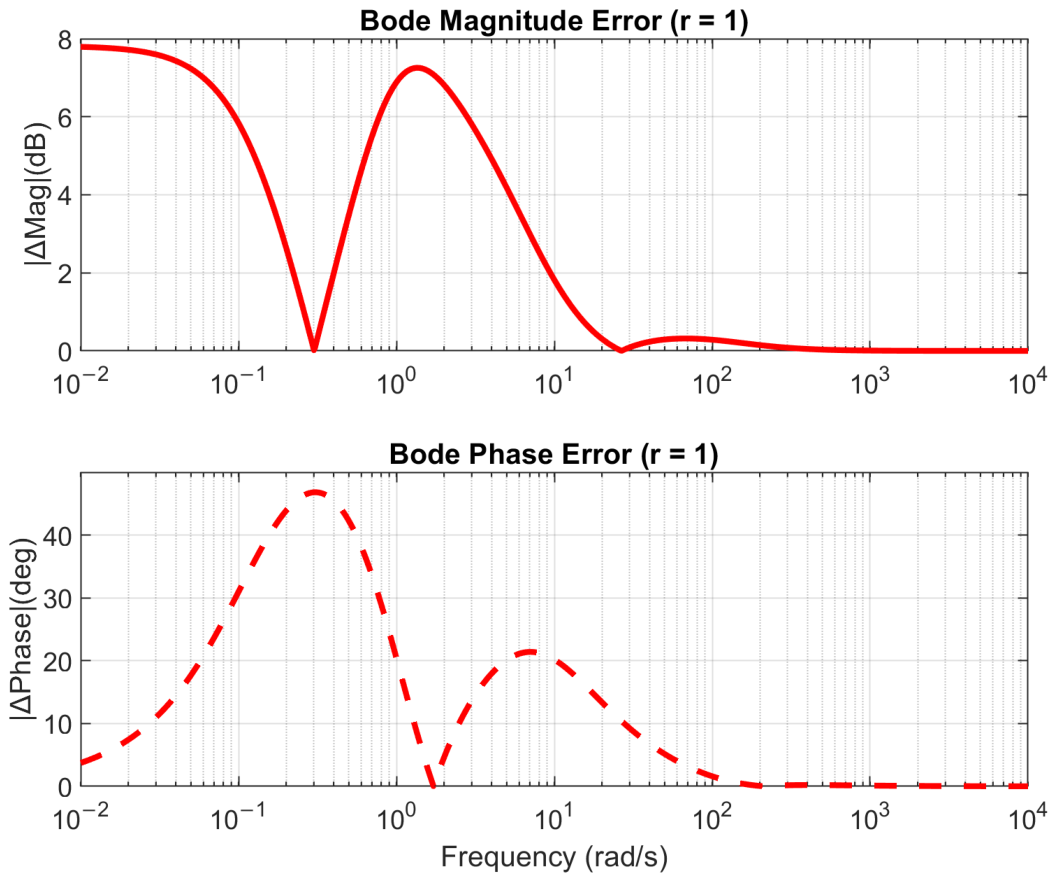
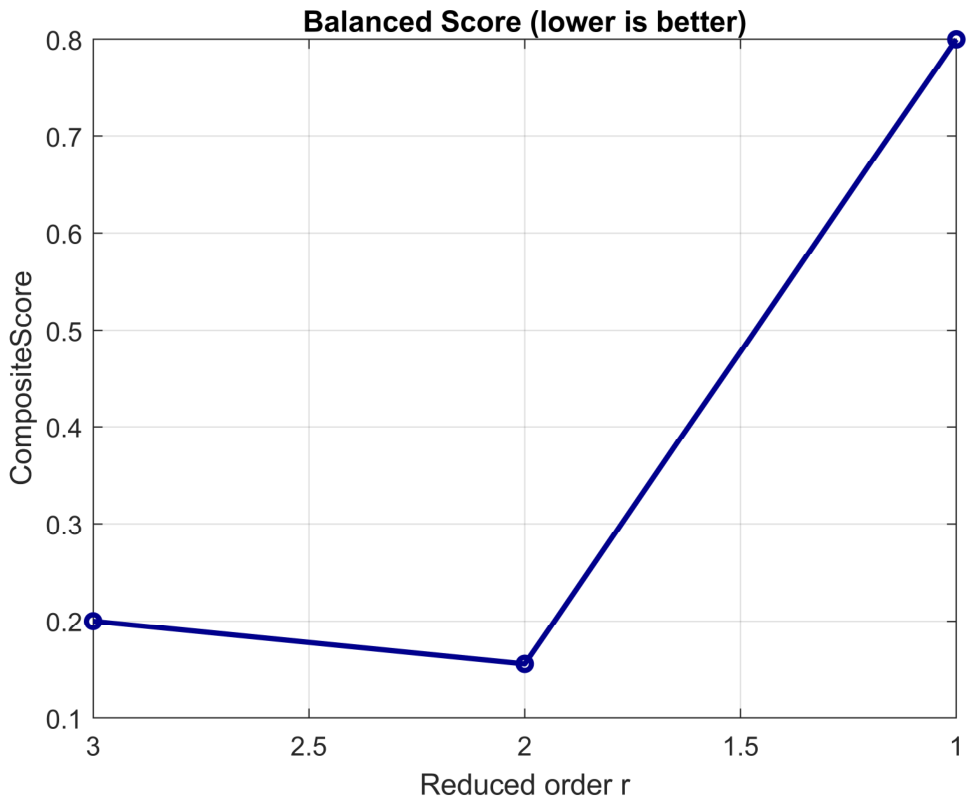
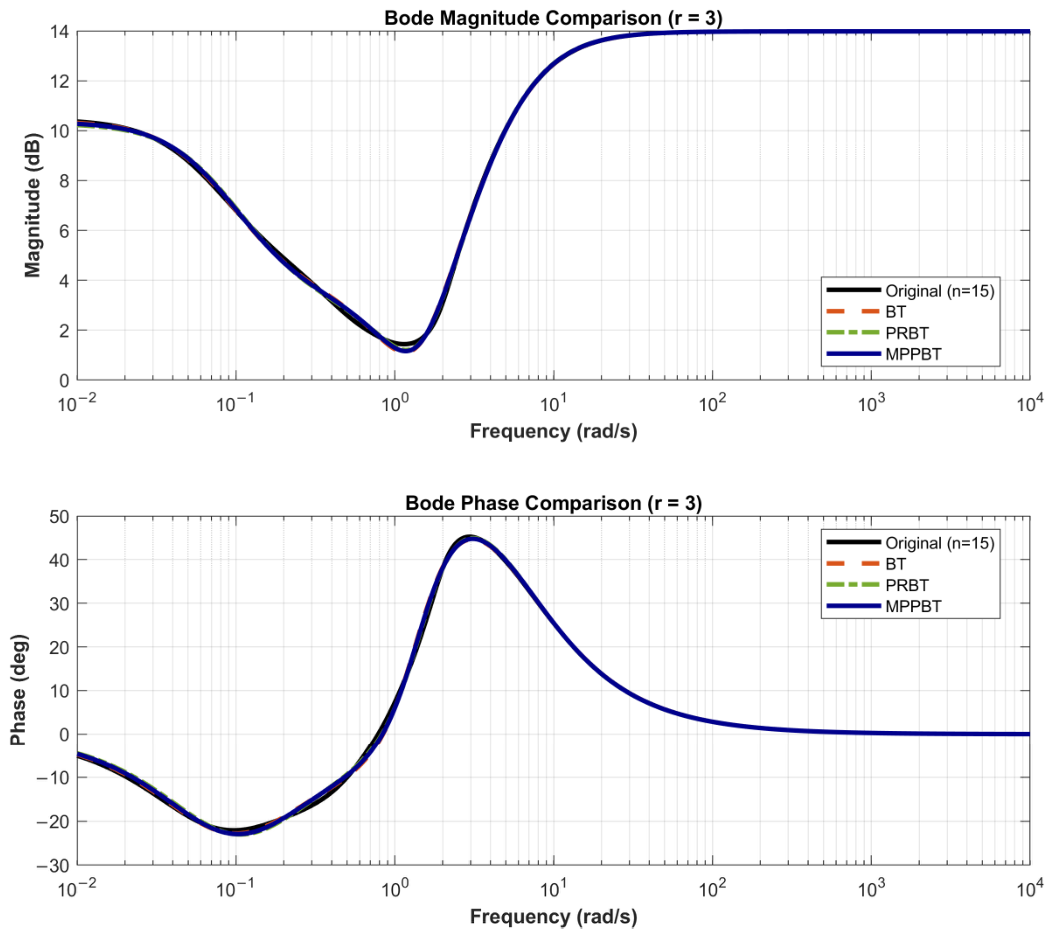
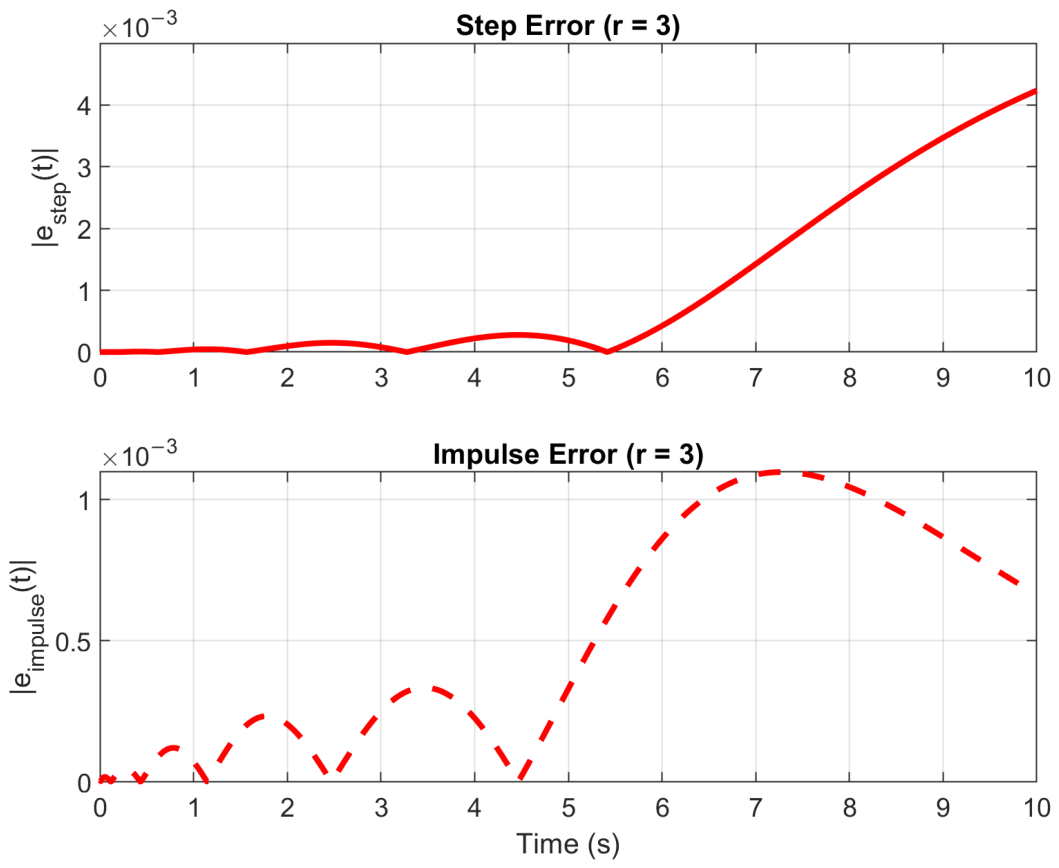
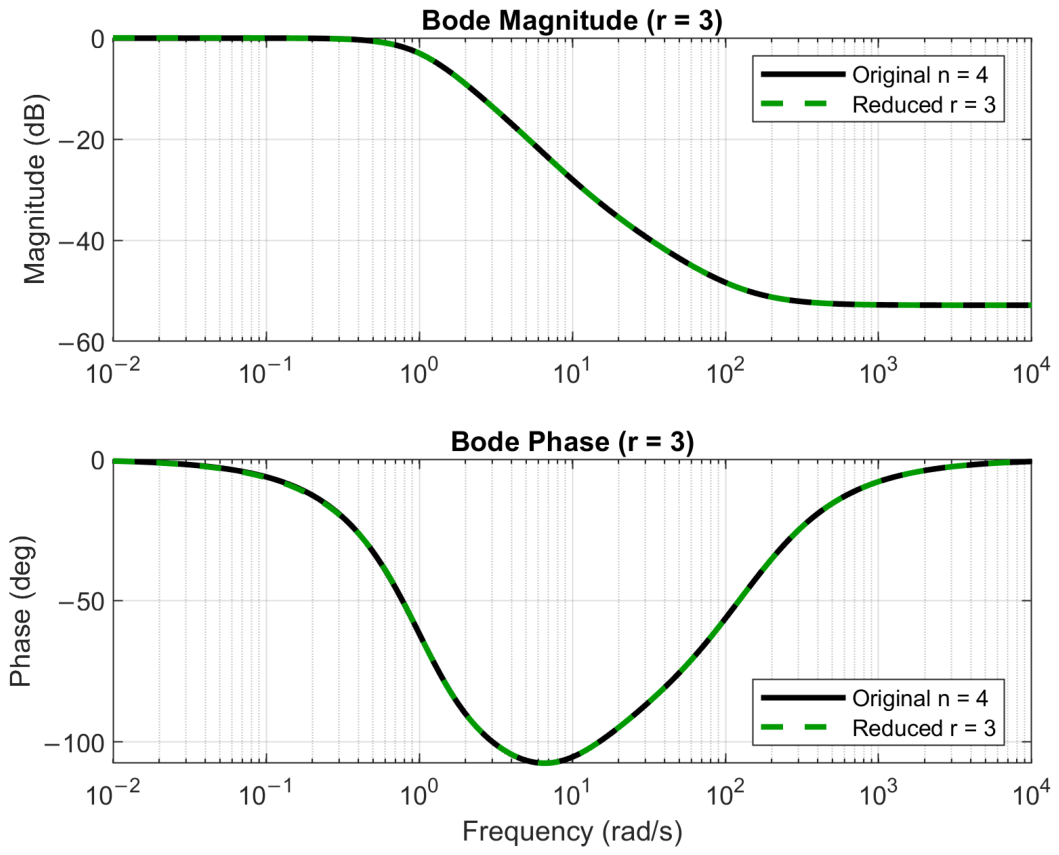
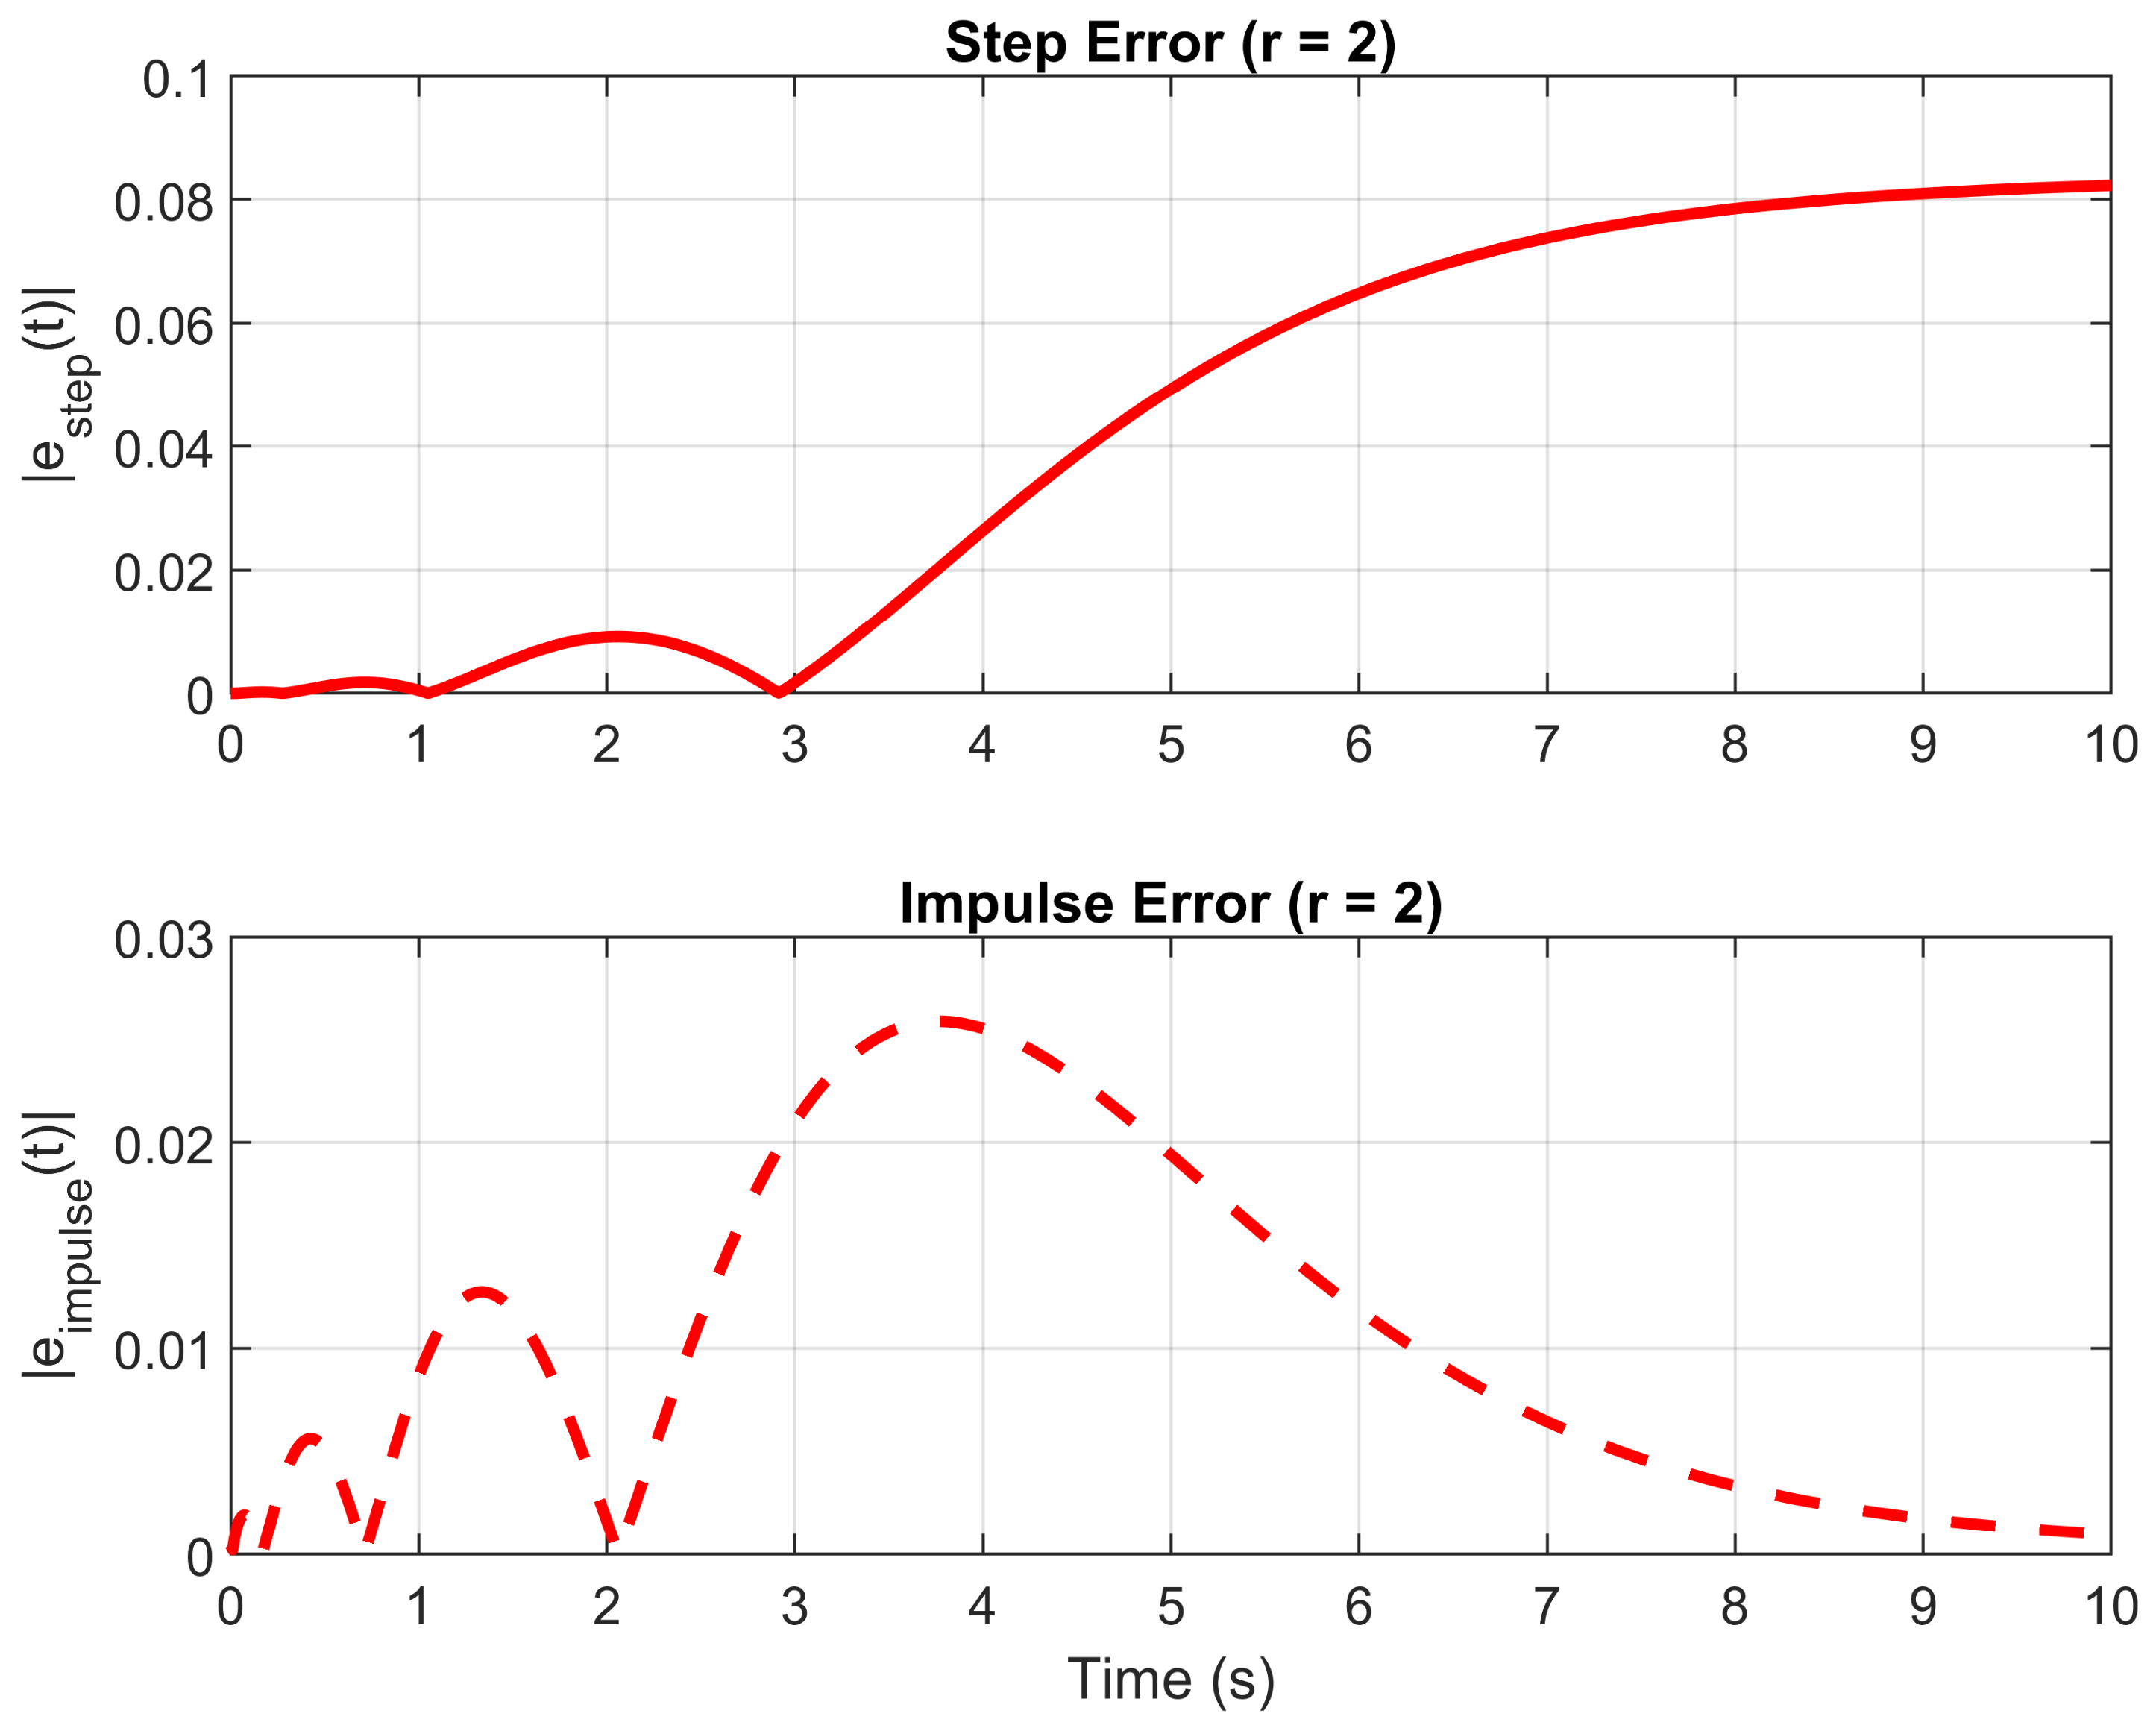
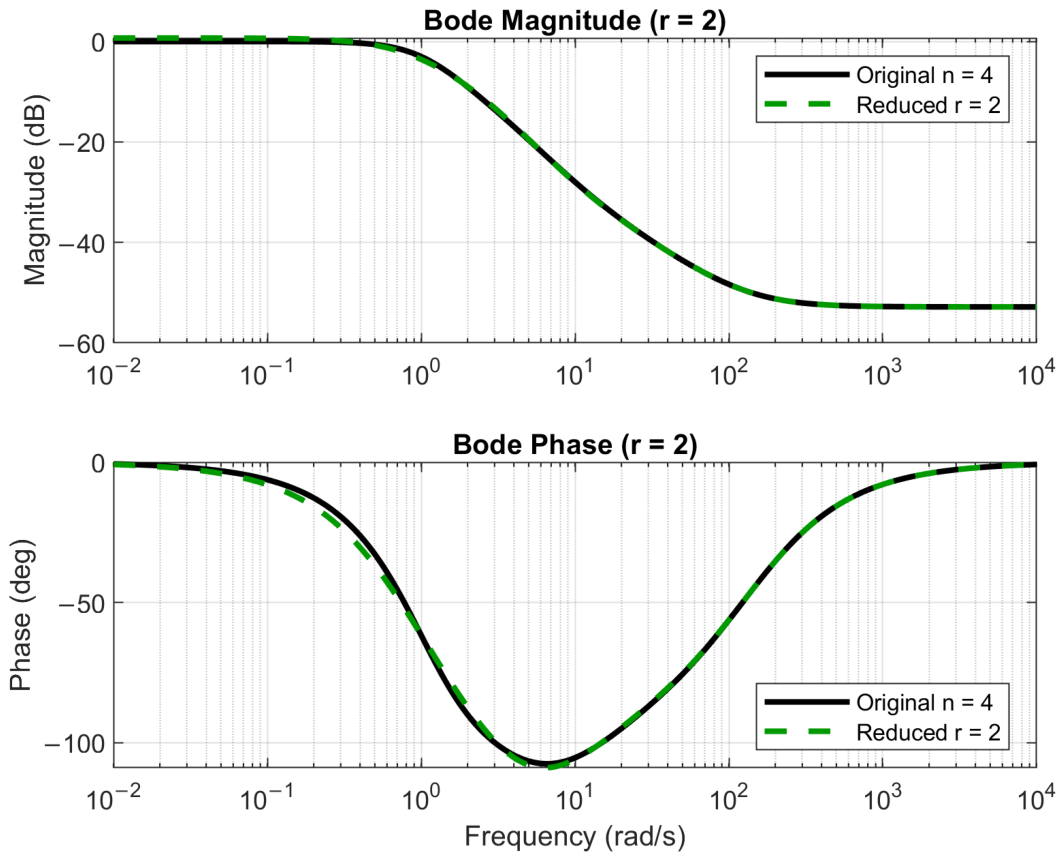
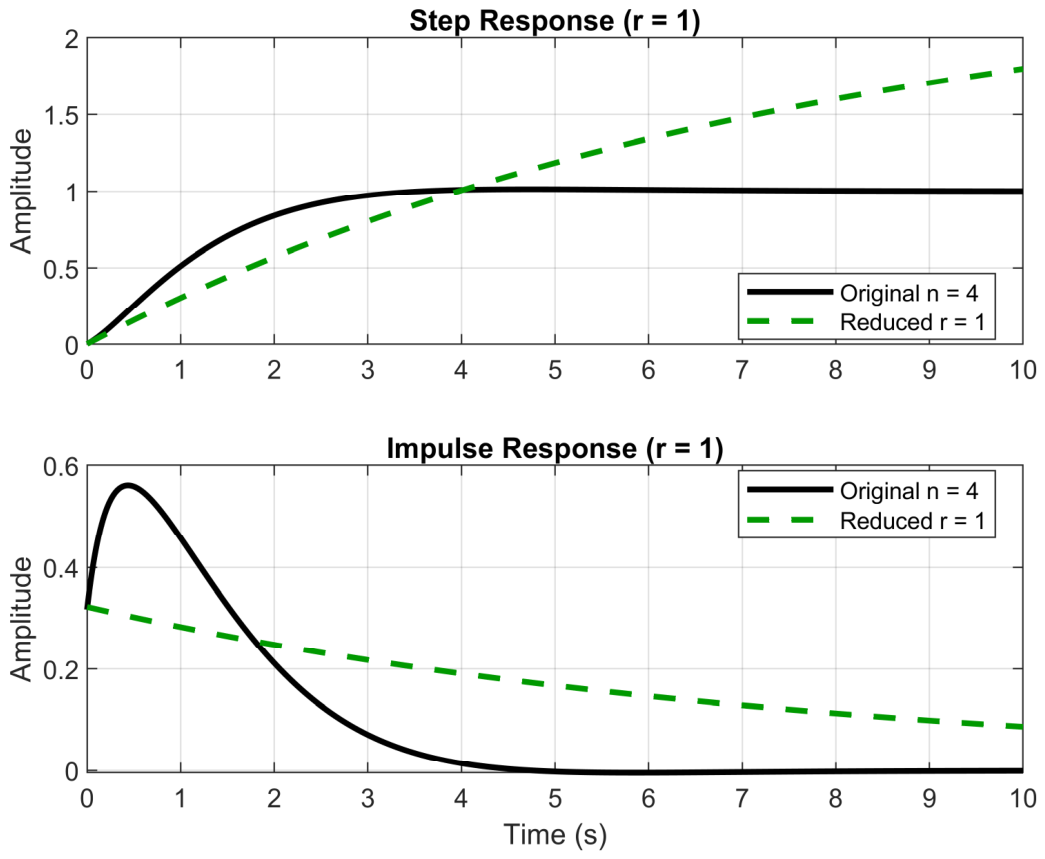
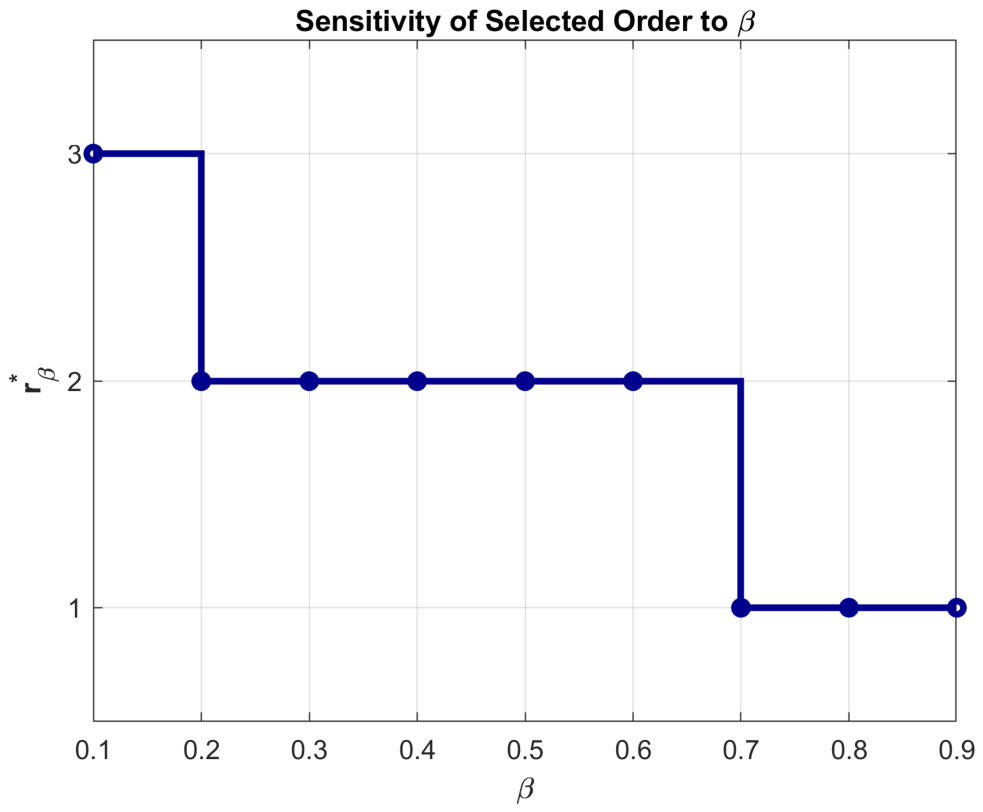
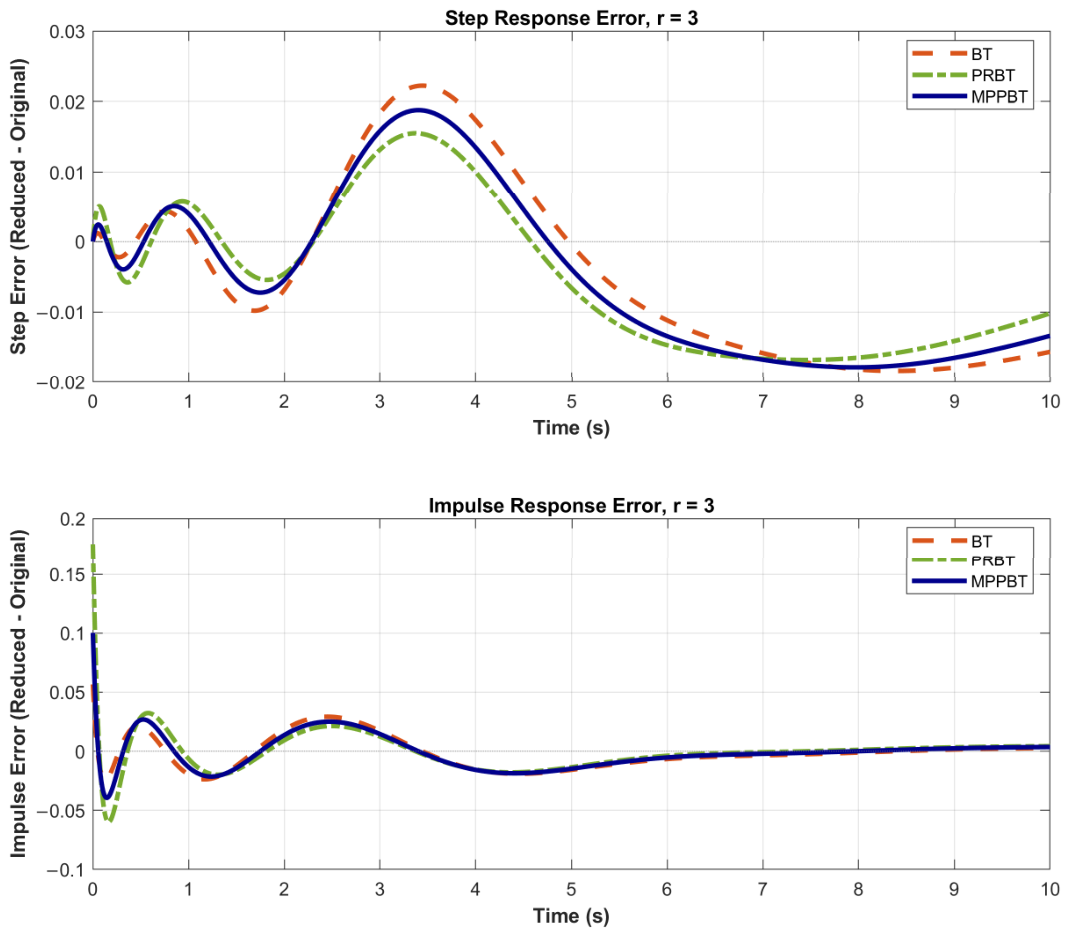
The numerical assessment applies this framework to a fourth-order Butterworth low-pass filter with and three reduced models with to examine in detail frequency-domain and time-domain errors and amplitude–phase indices. The third-order model yields and , whereas the first-order model gives and , leading to pronounced deviations in the step response, impulse response, and frequency response. A metric set of multi-criteria together with a min–max normalization mechanism and the score function under uniform weights and a fixed shows that the second-order model attains , which is lower than the third-order model with and much lower than the first-order model with , while preserving stability and the minimum-phase property of the original system. To further assess its accuracy relative to existing methods, MPPBT was compared with classical balanced truncation (BT) and positive-real balanced truncation (PRBT) on a 15th-order passive RLC ladder circuit at a common reduced order of . MPPBT achieved the smallest error, , compared with for BT and for PRBT, while its error of remained close to that of BT, . The Bode, step, and impulse responses further confirmed that MPPBT accurately reproduces the dominant frequency- and time-domain behavior of the full-order circuit. In addition, the sensitivity analysis of the trade-off parameter showed that the score-based order-selection procedure changes in an interpretable manner as the relative importance of approximation accuracy and model compactness varies. In particular, the nominal choice of lies in a stable interval in which the same reduced order is selected, supporting the robustness of the proposed scoring procedure.
These results open up the possibility of applying the MPPBT framework to multi-input multi-output systems in power electronic engineering and high-speed interconnect circuits where the minimum-phase structure plays a decisive role for control quality and design robustness. One direction focuses on refining the criterion vector and the weights in for RLC ladder circuits, high-order electromechanical systems, and industrial control systems with many state variables so that the scoring matches requirements on amplitude, phase, energy, and transient time more closely. One further direction emphasizes extending the MPPBT theoretical foundation to classes of stochastic bilinear or quadratic–bilinear systems combined with data-driven balancing and machine learning techniques in order to build a unified reduction scheme for large-scale minimum-phase systems in diverse engineering settings.