1. Introduction
In recent years, with the sustained development of the global economy and the deepening advancement of the “dual carbon” strategic goals, the new energy vehicle industry has encountered unprecedented development opportunities. With the continuous progress of electric drive technologies, electric vehicles are fully capable of realizing distributed drive configurations, i.e., driving each wheel directly via in-wheel motors or wheel-hub motors. Each wheel of a distributed-drive vehicle can be precisely torque-distributed by an independent motor, thereby enabling more flexible and sophisticated vehicle dynamics control. Owing to the aforementioned advantages, distributed-drive electric vehicles are considered one of the most promising electric vehicle architectures and also an ideal platform for research on advanced vehicle dynamics control technologies [
1].
At present, a variety of mature control technologies have been developed in the field of vehicle stability control. In the area of chassis dynamics control, DYC is naturally compatible with the characteristics of distributed-drive electric vehicles, enabling yaw and roll stability control through the combination of differential driving and braking without the need for additional subsystems [
2]. However, the core challenge in vehicle stability control lies in determining the vehicle’s stability boundaries, so as to rationally design the activation timing and control objectives of the controller [
3]. Currently, the commonly adopted methods for vehicle stability analysis and assessment mainly include the threshold method, Lyapunov stability analysis, and the phase-plane method [
4]. The threshold method utilizes vehicle state responses as stability criteria; however, in practical applications, it tends to cause frequent controller activation and deactivation, leading to torque chattering in the actuators [
5]. Although the Lyapunov stability analysis method possesses good theoretical robustness, its complex construction and heavy computational burden make it difficult to guarantee real-time performance under extreme operating conditions [
6]. The phase-plane method, owing to its intuitive visualization and unique advantages in nonlinear system analysis, has gained extensive attention and application in vehicle stability research [
7].
In recent years, the application of the phase-plane method to vehicle stability analysis has expanded from a single-dimensional framework to a multi-dimensional collaborative one. In [
8], an emergency collision avoidance system (ECAS) based on phase-plane regression regions was developed by extending the phase-plane approach with regression-region constraints, effectively overcoming the conservatism inherent in conventional phase-plane methods resulting from fixed inputs. In [
9], to address the issue that existing stability boundary delineation methods neglect the influence of front-wheel steering angle, an investigation into the lateral instability mechanisms of four-wheel-independent-drive vehicles was conducted, with the
phase-plane stability boundaries explicitly incorporating the front-wheel steering angle. In [
10], dynamic phase-plane boundaries were investigated from the perspective of tire characteristics, and both a quadrilateral stability region delineation method and a machine-learning-based stability region regression model were proposed. In [
11], an adaptive tube-MPC vehicle stability control approach based on extension phase-plane stability region partitioning was proposed, enabling dynamic decision-making of control objective weights and modes. In [
12], an observer-based robust MPC framework was developed, integrating phase-plane vehicle stability regions and control barrier function (CBF) constraints into the robust MPC formulation, thereby alleviating the online computational burden through offline solution. In [
13], an active front steering control method based on phase-plane stability boundary identification was proposed, in which a particle swarm optimization-back propagation (PSO-BP) neural network was employed to identify stability boundaries in the sideslip angle–yaw rate phase plane.
With regard to the integrated yaw and roll stability control of distributed-drive electric vehicles, recent research has evolved from single-objective stability control toward multi-objective collaborative control. In [
14], a coordinated control method based on adaptive-weight MPC was proposed, featuring a vehicle state estimator that fuses unscented Kalman filtering (UKF) with radial basis function neural networks (RBFNN), thereby achieving adaptive adjustment of the weights among trajectory tracking accuracy, yaw stability, and roll stability. In [
15], a yaw–roll coordinated control strategy based on adaptive model predictive control (AMPC) was proposed for distributed-drive commercial vehicles, where the control weights are dynamically and adaptively adjusted in real time through the analysis of modified
phase-plane boundaries and roll stability thresholds. In [
16], a hierarchical chassis stability coordination control framework based on adaptive model predictive control was proposed, in which a dynamic supervisory layer takes into account both yaw rate and handling limits when establishing the
phase-plane stability boundaries, and accordingly designs variable weighting factors. In [
17], an improved hierarchical control model predictive control (HC-MPC) algorithm was designed for H-type distributed-drive electric vehicles, integrating energy-saving and stability control algorithms on the basis of an enhanced phase-plane stability criterion.
In the domain of coordinated control between active steering and torque vectoring, relevant studies have also provided important references for integrated control. In [
18], the control capability of vehicle yaw stabilization systems was systematically analyzed based on scalar fields, with the control capability regions of ARS, rear torque vectoring (RTV), and ESC defined in the sideslip angle–yaw rate phase plane. In [
19], an adaptive coordinated controller for ARS and TVC based on the energy phase plane and Lyapunov’s second method was proposed, which establishes an extended stability envelope that accounts for actuator effects and performs dynamic allocation according to actuator effectiveness. In [
20], a cooperative control strategy for torque vectoring and rear wheel steering is proposed based on phase-plane analysis. By defining performance indices to quantify the weighting of each actuator’s influence on vehicle states and dynamically allocating the control authority according to varying driving conditions, the proposed strategy achieves superior yaw stability and sideslip angle control compared with either actuator acting alone. In [
21], a coordinated control strategy for ARS and DYC based on extension phase-plane stability region partitioning was proposed, where the phase plane is introduced to enable adaptive partitioning of the extension boundaries. In addition, the influence of road conditions on phase-plane stability boundaries has also attracted attention. In [
22], the effects of road banking angle on the planar motion stability of nonlinear vehicle models were investigated, demonstrating that saddle-node bifurcations may occur when the vehicle travels on banked roads, thereby affecting the yaw stability region. This line of research has prompted new reflections on the applicability of phase-plane stability boundaries under complex road conditions [
23]. In the area of rollover prediction and control, integrated path-following and rollover prevention control methods based on MPC were proposed in [
24], with the effectiveness of the control strategies validated under complete failure conditions of the steering motor. In [
25], a predictive time algorithm based on phase-plane ISO-LTR characteristic lines is proposed for rollover prediction of heavy vehicles, which computes the time to reach the rollover threshold in real time through the geometric relationship of constant load transfer ratio contours in the phase plane, and employs a recurrent neural network to estimate the load transfer ratio from conventional on-board sensor signals. In [
26], a MPC-based roll-over prevention system is designed, where the rollover index is treated as a soft constraint to ensure persistent feasibility, and a real-time roll angle estimator is developed by fusing vehicle kinematics with roll dynamics, with experimental validation conducted under fishhook and double-lane change maneuvers via torque vectoring.
Nevertheless, the existing phase-plane-based integrated control strategies still suffer from the following deficiencies: (1) In most approaches, mode switching is triggered based on the single-point state at the current instant, failing to fully exploit the state trajectory information within the prediction horizon for proactive anticipation [
27]. (2) The adjustment of control weights is largely dependent on empirical settings or heuristic rules, lacking an adaptive mechanism based on the joint distribution of yaw and roll instability risks over the prediction horizon [
28]. (3) Yaw stability assessment and roll stability assessment are often conducted independently, without achieving deep coupling and collaborative decision-making within a unified predictive control framework [
29].
To address the aforementioned issues, this paper takes distributed-drive electric vehicles as the research subject and proposes a phase-plane-based yaw and roll stability integrated control (Yaw-Roll Integrated Control, YRIC) strategy. The main contributions of this paper are threefold: (1) Both the phase plane and the phase plane are concurrently employed for stability assessment, with control triggering based on state trajectories over the prediction horizon rather than single-point states, thereby enabling proactive anticipation of yaw and roll instability risks; (2) Four control modes are designed, and the decision-making layer adaptively adjusts the weighting coefficients in the MPC cost function according to the joint distribution of the yaw stability index and the roll stability index over the prediction horizon, achieving dynamic prioritization of control objectives; (3) The phase-plane stability assessment, MPC-based optimization control, and tire force allocation are decoupled into independent functional modules with well-defined interfaces between layers, striking a balance between control performance and engineering deployability. The effectiveness of the proposed integrated control strategy is validated through co-simulations using MATLAB/Simulink2021b and CarSim2020 under various representative driving scenarios.
2. Vehicle Dynamics Model
2.1. Vehicle Dynamics Model for Integrated Controller Design
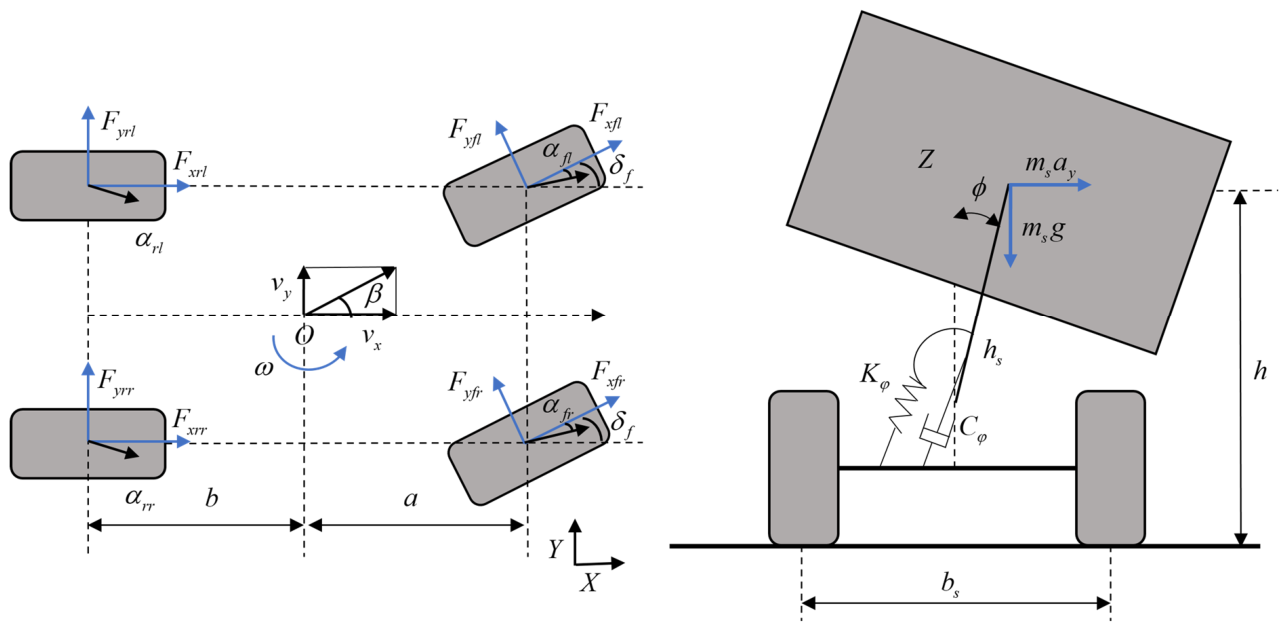
The 4-DOF dynamics model considered in this paper includes longitudinal, lateral, yaw, and roll motions, as shown in
Figure 1. On this basis, the following assumptions are made: (1) vertical motion of the vehicle is neglected, and the vehicle is assumed to be traveling on a level road; (2) the nonlinear characteristics of the vehicle suspension are ignored, and it is simplified as equivalent roll stiffness and damping coefficients; (3) the influence of aerodynamic drag is neglected; (4) the steering system is disregarded, and the steering wheel angle is directly transformed into the front wheel steering angle input.
Vehicle longitudinal motion:
where
vx and
vy are the longitudinal and lateral velocities of the vehicle, respectively;
ω is the yaw rate;
m and
ms are the total vehicle mass and the sprung mass, respectively;
hs is the distance from the center of gravity to the roll center;
ϕ is the vehicle body roll angle;
δf is the front wheel steering angle;
Fxij denotes the tire longitudinal forces, and
Fyij denotes the tire lateral forces.
Vehicle yaw motion:
where
Iz is the yaw moment of inertia of the vehicle;
bs is the track width;
a and
b are the distances from the vehicle center of gravity to the front axle and to the rear axle, respectively.
Vehicle roll motion:
where
Ix is the roll moment of inertia of the vehicle body;
Kϕ is the equivalent roll stiffness of the suspension; and
Cϕ is the equivalent roll damping coefficient of the suspension.
The vehicle parameters required in this paper are listed in
Table 1.
2.2. Stability Analysis Based on the Yaw Phase Plane
The linear two-degree-of-freedom model neglects the nonlinear characteristics of tires and treats tire cornering stiffness as constant values, with the vehicle having only two degrees of freedom, namely yaw motion and lateral motion. When conducting phase plane analysis of vehicle states, it is generally necessary to consider the nonlinear characteristics of the actual vehicle in operation, and the nonlinear features of the actual vehicle mainly originate from the nonlinear region of tires. In this paper, a nonlinear two-degree-of-freedom vehicle model is established by introducing a nonlinear tire lateral force model, which serves as the yaw phase plane model of the vehicle.
The dynamic equations of the nonlinear two-degree-of-freedom model are as follows:
where
Fyf and
Fyr are the front and rear tire lateral forces of the two-degree-of-freedom model, respectively, and
β is the vehicle sideslip angle. The tire lateral forces are calculated using the magic formula. The established nonlinear two-degree-of-freedom model, with sideslip angle and yaw rate as state variables, can be expressed as the following second-order system:
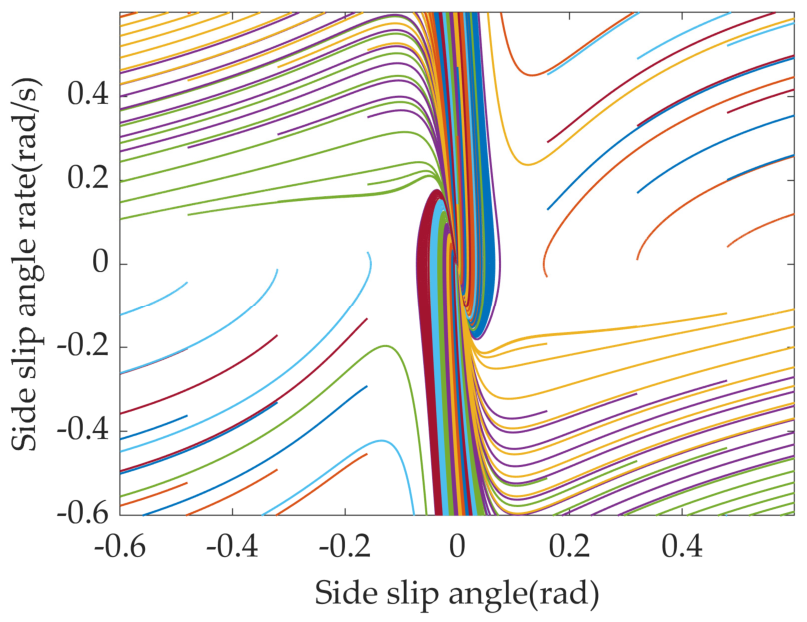
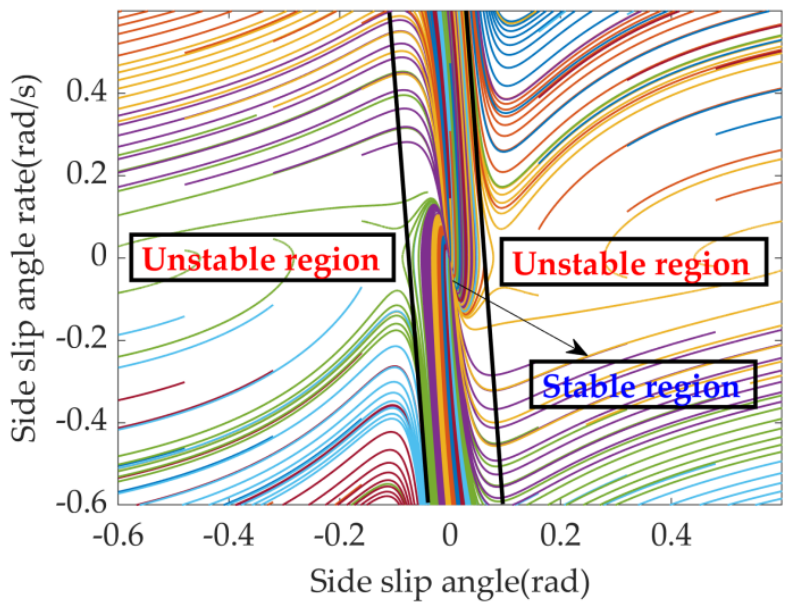
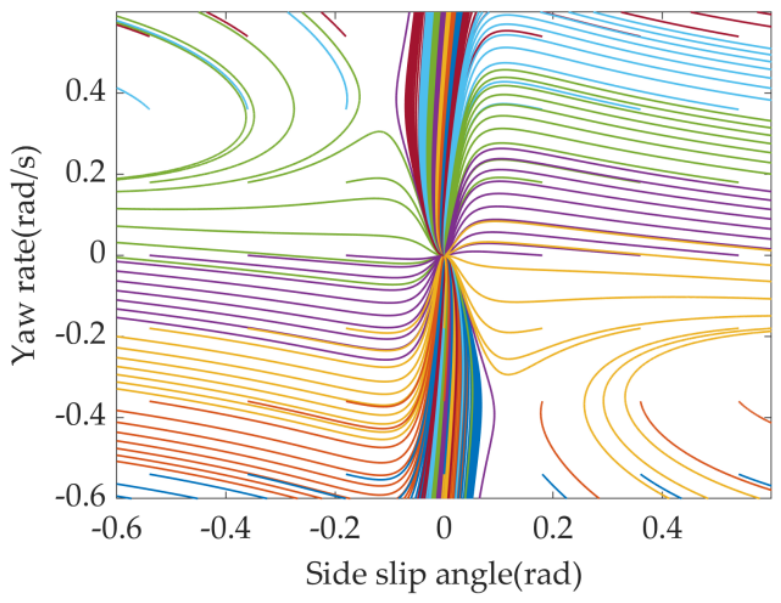
Based on the phase plane theory, using the nonlinear dynamics in Equation (6) with tire lateral forces computed by the Pacejka magic formula. The
phase plane diagrams and
phase plane diagrams under different longitudinal vehicle speeds and front wheel steering angles can be obtained via fourth-order Runge–Kutta numerical integration. Fixing vehicle speed
vx, front-wheel steering angle
δf, and road adhesion coefficient
μ, the
phase plane diagrams and
phase plane diagrams are as shown in
Figure 2 and
Figure 3.
The region in the phase plane where trajectories converge to the equilibrium point is defined as the stable region, and its size is mainly influenced by longitudinal vehicle speed, front wheel steering angle, and road adhesion coefficient. For the stable region of the phase plane, the longitudinal vehicle speed, front wheel steering angle, and road adhesion coefficient all have significant effects, making it difficult to derive the relationship between the stable region and these three influencing factors. Therefore, the phase plane is selected as the basis for vehicle yaw stability judgment in this paper.
2.3. Stability Analysis Based on the Roll Phase Plane
The rollover index is mainly used to characterize the vehicle’s roll state, and the judgment of vehicle rollover is achieved through the magnitude of the rollover index, which is a quantitative evaluation method. The phase plane method is an effective approach for analyzing the vehicle stability region. During the vehicle roll motion, the roll angle can indicate rollover risk, and the roll angular velocity can predict the variation in roll angle to a certain extent. The roll phase plane diagram can simultaneously incorporate both pieces of information, which is beneficial for vehicle control.
Vehicle roll dynamics equation:
where
ay is the vehicle lateral acceleration;
ϕw is the vehicle body roll angle when the wheel is lifted; and
Ix1 is the roll moment of inertia about the wheel contact point after the wheel is lifted.
The discontinuity in Equation (7) reflects the change in the vehicle roll dynamics model before and after wheel lift-off. When the roll angle ϕ < ϕW, the vehicle rotates about the roll axis at the center of gravity height, and the suspension stiffness and damping provide the restoring moment. When ϕ ≥ ϕW, the inner wheel lifts off the ground, and the vehicle rotates about the contact point of the outer wheel. In this regime, the suspension contribution vanishes, and the restoring moment is provided by the gravity component.
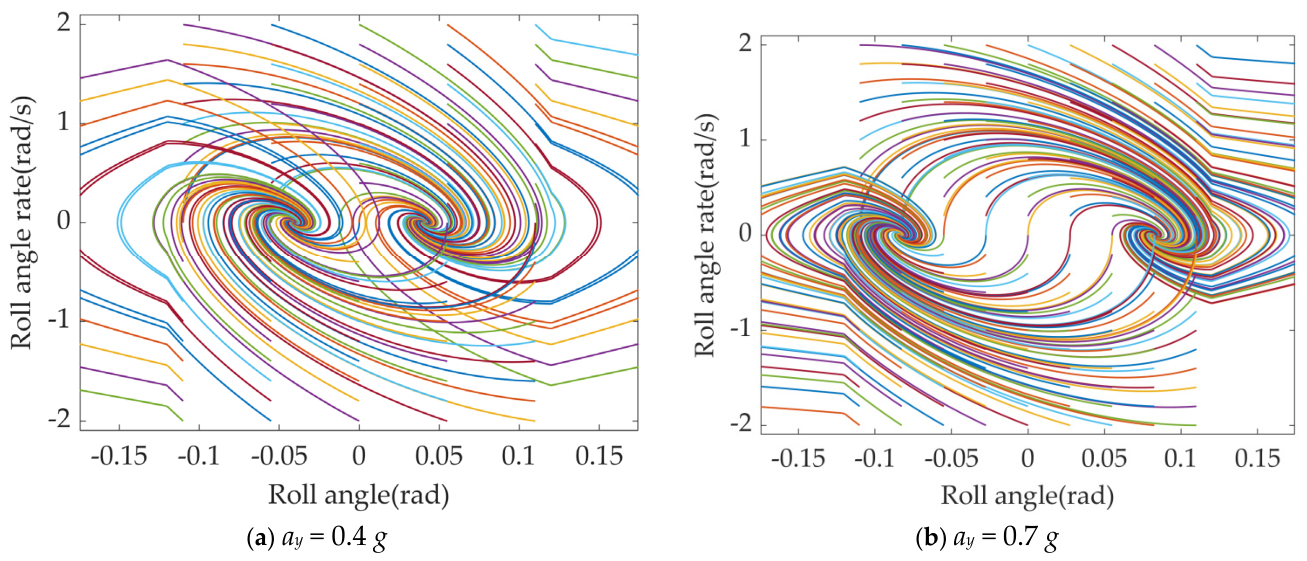
The determination of the stable region in the phase plane depends on the critical lateral acceleration and critical roll angle obtained from static rollover analysis of the vehicle. This critical state is related to the vehicle’s structural parameters. On one hand, as the roll angle increases, the lateral acceleration required to induce rollover decreases; on the other hand, an increase in lateral acceleration also leads to a larger roll angle. The specific formulas are as follows:
By solving Equations (8) and (9) simultaneously, the critical lateral acceleration and critical vehicle roll angle for static rollover can be obtained. Based on the lateral acceleration and Equation (7), the vehicle body
phase plane diagrams can be obtained.
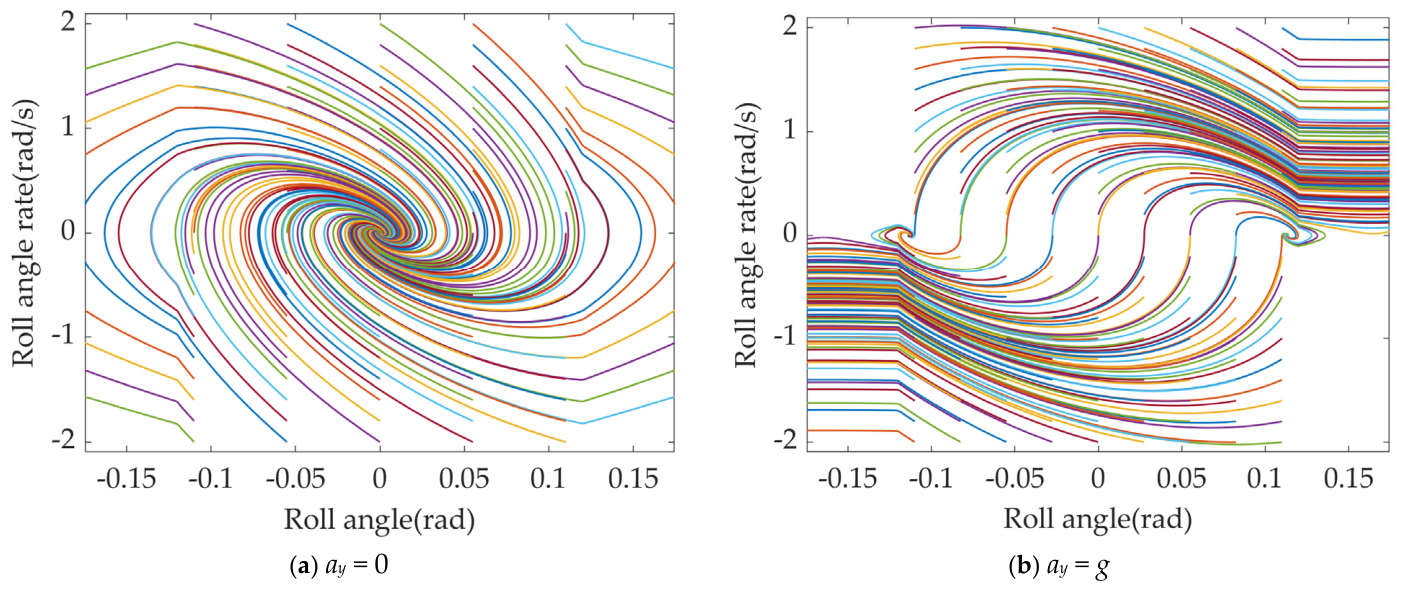
Figure 4 shows the
phase plane diagrams under two different lateral acceleration levels.
The most commonly used rollover indicator is the lateral load transfer ratio (
LTR) based on vehicle dynamics. This indicator represents the relationship between the difference in vertical loads on the left and right wheels and the total load, and its expression is as follows [
30]:
where
Fzl and
Fzr denote the vertical loads on the left and right sides of the vehicle, respectively. When
LTR is less than 1, both sides of the wheels remain in contact with the ground, and the vehicle is considered to be within the safe region of roll; otherwise, it indicates wheel lift and is regarded as rollover occurrence. Considering that tire vertical loads are difficult to measure, they are usually approximated as:
In this paper, for non-trip-induced rollover of distributed-drive electric vehicles, direct yaw moment control is adopted to reduce the lateral acceleration by decreasing the vehicle yaw rate, thereby achieving roll stability control. The phase plane is selected as the basis for vehicle roll stability judgment, and LTR is chosen as the control output of the integrated controller.
2.4. In-Wheel Motor Model
The drive motor used in this paper is a permanent magnet synchronous in-wheel motor. The characteristic parameters of the in-wheel motor are shown in
Table 2.
The maximum driving force of the in-wheel motor mentioned in the controller designed later in this paper is converted from the motor peak torque via the tire rolling radius: F
dmax = Peak torque/
rw = 650/0.325 = 2000 N. Considering that only motor dynamics control is required in this paper, and the instantaneous response speed of the motor drive control is much faster than that of the wheels, the electromagnetic conversion process of the drive motor is omitted and simplified as a second-order response system. Its transfer function is:
where
Tm is the actual electromagnetic torque input to the motor,
Td is the desired electromagnetic torque input to the motor, and
ξ is the physical characteristic parameter of the in-wheel motor. In this paper, the value of
ξ is 0.001.
3. Integrated Control Strategy Design
3.1. Overall Framework of Integrated Yaw and Roll Stability Control
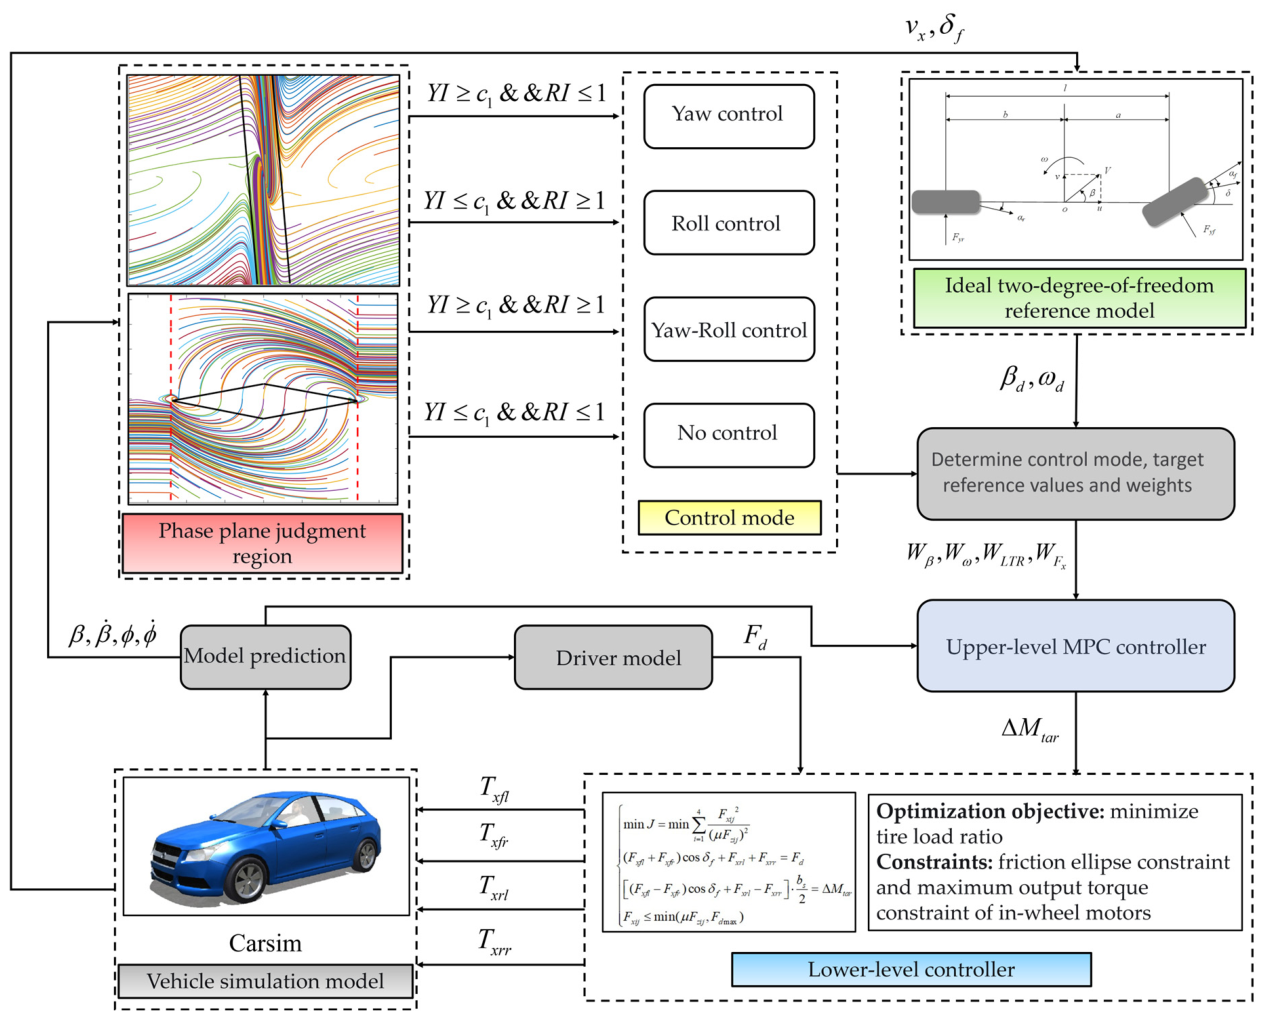
The integrated controller proposed in this paper employs a predictive model to forecast the vehicle states over a finite future horizon, and triggers control mode switching based on the relative position between the predicted state trajectories and the stability boundaries defined in the phase plane. The optimal control mode is selected from four available candidates. Within a unified predictive control framework, stability assessments are concurrently conducted using both the phase-plane method and an additional stability criterion. The decision-making layer then performs a logical synthesis of the two assessment results, thereby achieving unified management and synergistic suppression of both yaw instability and roll instability risks.
The integrated control logic for vehicle yaw and roll stability is illustrated in
Figure 5. The
phase plane and the
phase plane are respectively divided into stable and unstable regions. Based on the current vehicle state, the prediction model calculates the sideslip angle, sideslip angular velocity, body roll angle, and roll angular velocity within the prediction horizon, and judges the vehicle state within that horizon. The decision-making layer switches the corresponding vehicle control mode according to the vehicle state. The upper-level MPC controller computes the desired yaw rate and desired sideslip angle based on the longitudinal vehicle speed and front wheel steering angle, and simultaneously assigns the corresponding control weighting factors according to the control mode determined by the decision-making layer. Under the constraint of the friction ellipse, considering the minimum deviation of the total longitudinal force, yaw rate, sideslip angle, and lateral load transfer ratio from their target reference values within the prediction horizon, the optimal control outputs are achieved. The desired additional yaw moment is then calculated from the desired tire longitudinal forces that are output. The lower-level controller optimizes and allocates the obtained additional yaw moment to the four wheels to correct the vehicle state.
3.2. Division of the Stable Region in the Yaw Stability Phase Plane
The double-line method is a widely used approach for stability region division. The stable region in the
phase plane can be specifically expressed by the following formula:
where
k1 and
c1 are the boundary parameters of the stable region, and their values vary under different operating conditions.
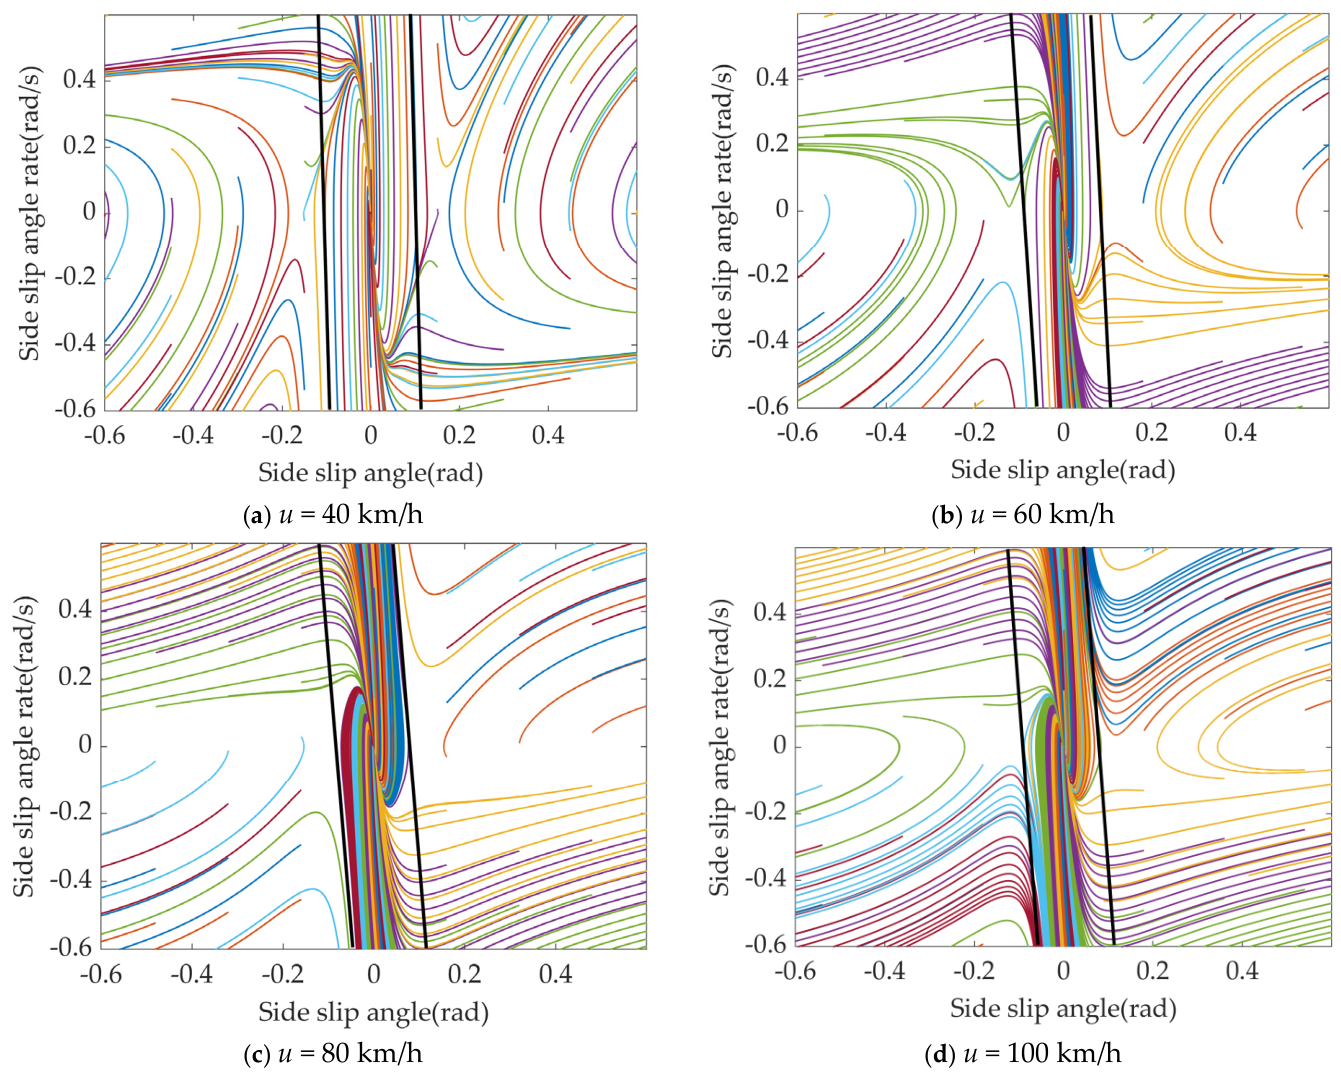
Figure 6 illustrates the
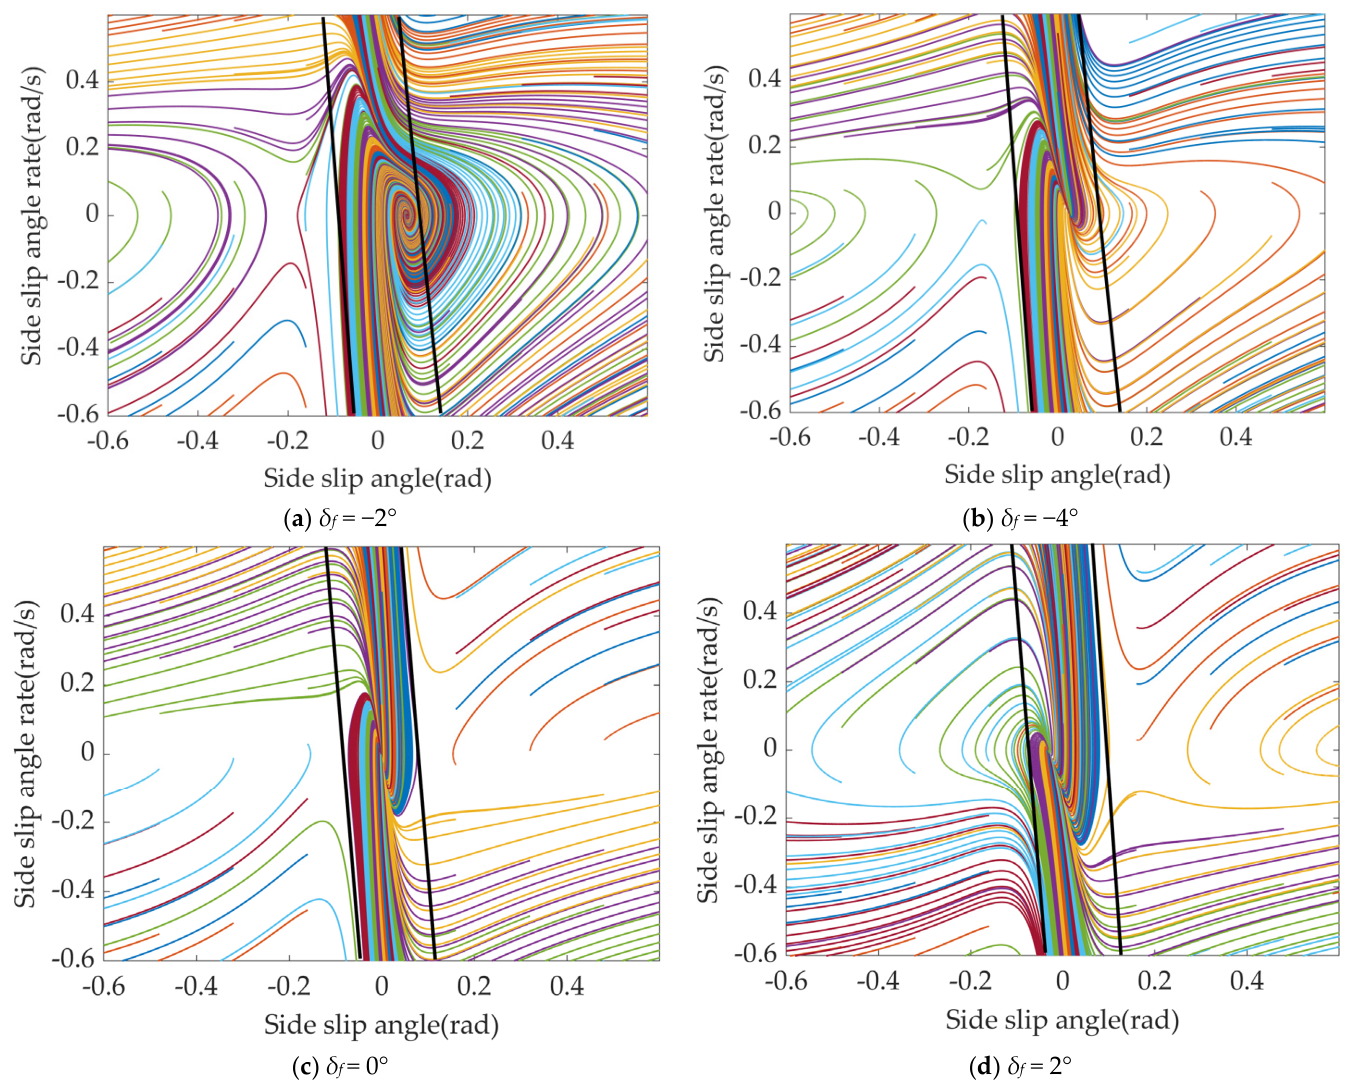
phase-plane stability region boundaries under a road adhesion coefficient of 0.8 and a front-wheel steering angle of 0°, with longitudinal vehicle speeds of 40, 60, 80, and 100 km/h, respectively.
Figure 7 presents the
phase-plane stability region boundaries under a road adhesion coefficient of 0.8 and a longitudinal vehicle speed of 80 km/h, with front-wheel steering angles of −4°, −2°, 0°, and 2°, respectively.
Figure 8 shows the
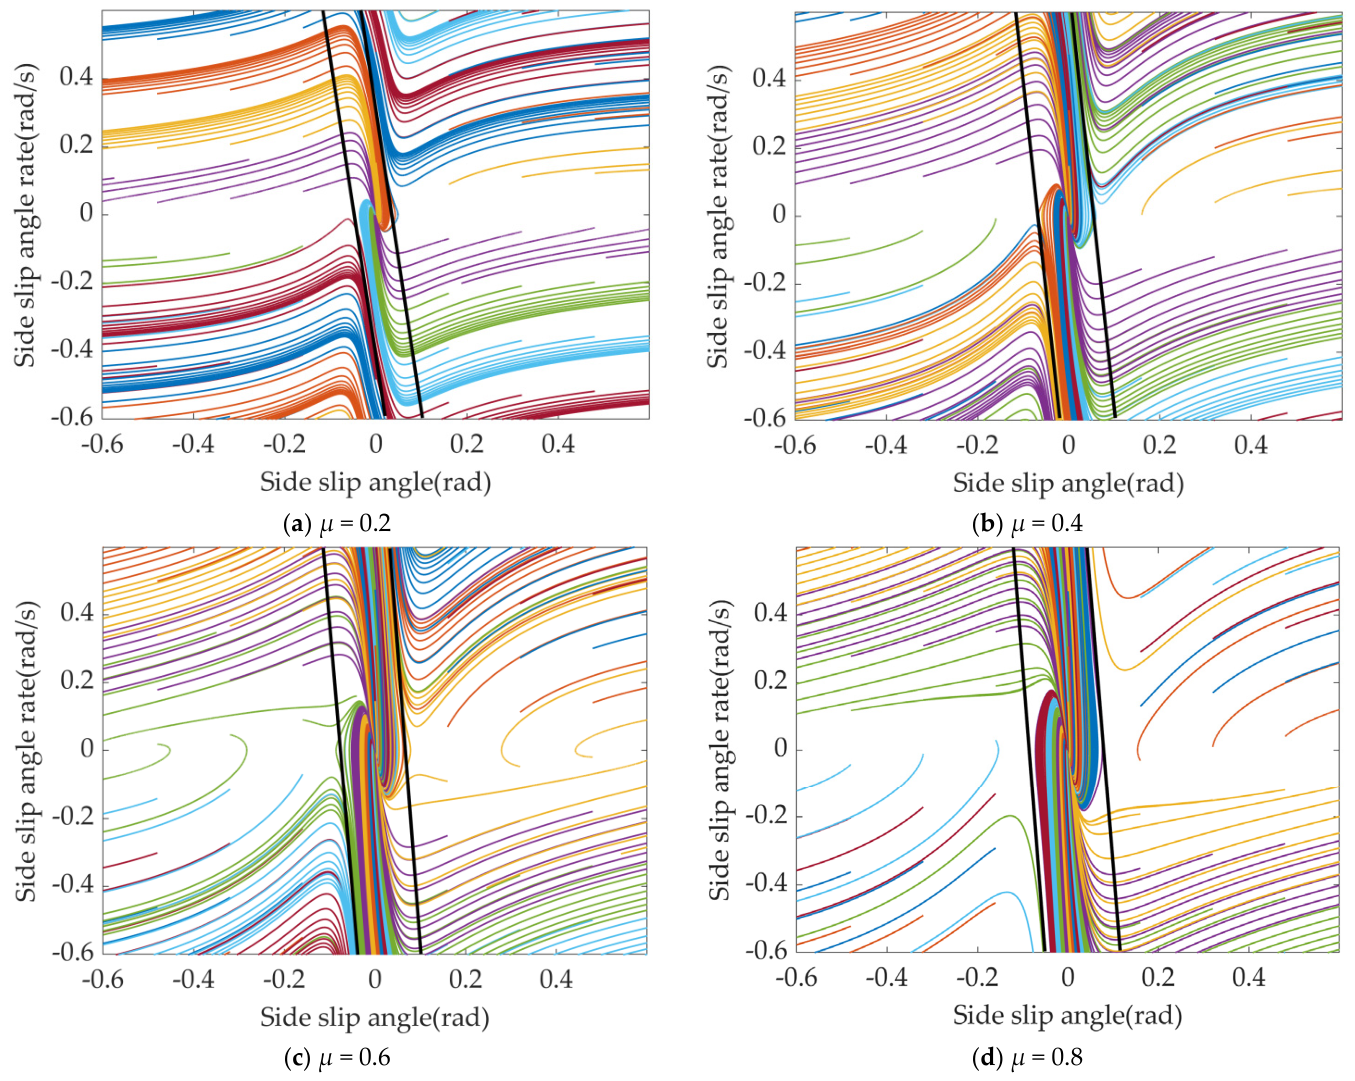
phase-plane stability region boundaries under a longitudinal vehicle speed of 80 km/h and a front-wheel steering angle of 0°, with road adhesion coefficients of 0.2, 0.4, 0.6, and 0.8, respectively.
From the phase-plane stability region boundary diagrams under the above three operating conditions, it can be observed that the road adhesion coefficient has a significant influence on the size of the phase-plane stability region, whereas the longitudinal vehicle speed and the front-wheel steering angle have a relatively minor effect on the size of the stability region.
The value of
k1 is calculated by averaging the slopes of multiple convergent phase trajectories, and the value of
c1 is obtained from the distribution diagram of initial stable phase points. The obtained stable region boundary parameters are summarized to yield the boundary parameters of the
phase plane stable region under different road adhesion coefficients. The specific values are shown in
Table 3.
According to the data in the table, the polynomial boundary equation coefficients
k1 and
c1 are obtained by using the MATLAB polynomial curve fitting function to fit the data in the least-squares sense, as shown below:
Based on the double-line method, the
phase plane is divided into stable and unstable regions, as shown in
Figure 9. The region inside the double lines is the stable region, and the region outside is the unstable region. Since the longitudinal vehicle speed and the front wheel steering angle have little influence on the size of the stable region in the
phase plane, their effects are neglected in this paper, and only the influence of the road adhesion coefficient is considered. Finally, the
phase plane with the stability region divided is used as the basis for vehicle yaw stability judgment.
3.3. Division of the Stable Region in the Roll Stability Phase Plane
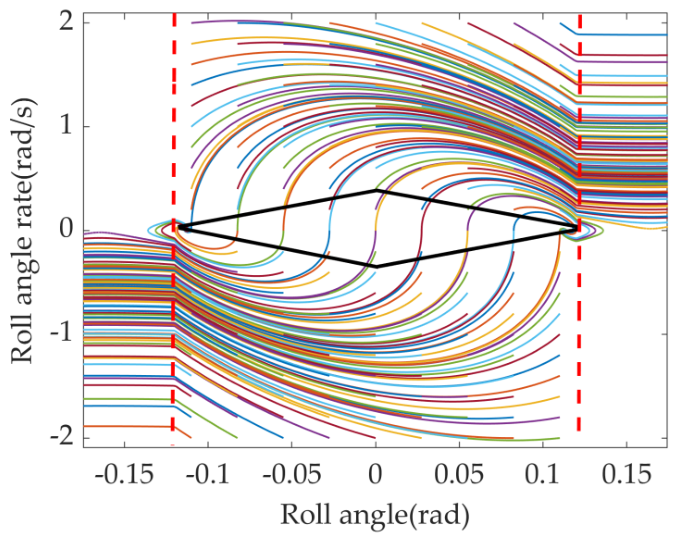
The size of the stable region in the roll stability phase plane is mainly affected by the vehicle lateral acceleration. Two special roll stability phase plane diagrams under two lateral acceleration levels are considered: one with zero lateral acceleration, and the other with the critical lateral acceleration, as shown in
Figure 10.
The double-line method can roughly divide the stable and unstable regions in the phase plane. However, according to the convergence characteristics of the trajectories in the phase plane, there exist many divergent trajectories within the stable region delineated by the double-line method. This issue is particularly evident in the phase plane diagram at the critical lateral acceleration, where trajectories exceeding the critical roll angular velocity are all in a divergent state. The rhombus method can be adopted to divide the stable region of the phase plane to address the above problem.
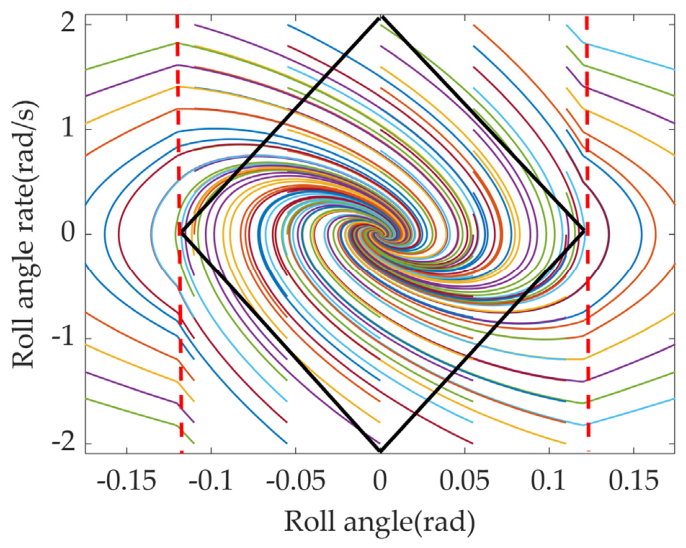
Figure 11 shows the
phase plane diagram at zero lateral acceleration. The two vertical red dashed lines on the left and right sides represent the static critical roll angles of the vehicle body. Exceeding this value would cause wheel lift, indicating that the vehicle is about to roll over. In the phase plane, the two trajectories that critically converge to the stable equilibrium point are connected with the intersections on the zero-roll-angle axis and the zero-roll-angular-velocity axis, forming two inclined straight line segments, which are then connected to form a rhombus. In the phase plane diagram, the interior of the rhombus is defined as the stable region, while the exterior is defined as the unstable region.
Generally, during the process of rollover instability, the vehicle’s lateral acceleration reaches the critical value.
Figure 10 shows the
phase plane diagram of the vehicle body at the critical lateral acceleration. Similar to
Figure 11, the critical roll angle intersecting the horizontal axis and the critical roll angular velocity intersecting the vertical axis can be determined from the two critically convergent trajectories. In this case, the vehicle roll stability region lies within the rhombus connecting the critical roll angle and the critical roll angular velocity. This region is evidently smaller than that enclosed at zero lateral acceleration in
Figure 11, and can more accurately reflect the state boundary of the vehicle at the critical rollover condition. Moreover, the limit values for state control can be obtained from the region boundaries. Therefore, the
phase plane diagram at the critical lateral acceleration is adopted in this paper for roll stability judgment.
The stability region boundary in
Figure 12 can be expressed by the following formula:
where
and
denote the critical roll angle and critical roll angular velocity determined by the stable region of the roll phase plane, respectively. In the above formula, both the critical roll angle and the critical roll angular velocity are taken as positive values. Generally, when the vehicle loses roll stability, it directly leads to rollover. In order to ensure vehicle roll stability, both the critical roll angle and the critical roll angular velocity in Equation (15) need to be multiplied by a safety factor. The absolute value of the critical roll angle is 5.7 deg, the absolute value of the critical roll rate is 17.2 deg/s, and the safety factor is taken as 0.5.
3.4. Decision-Making Layer
The decision-making layer mainly performs switching among different control modes based on the stability region boundary functions of the
phase plane and the
phase plane. Within the prediction horizon, the decision-making layer evaluates the vehicle states at each sampling instant. The corresponding control mode is triggered as soon as any predicted state point within the horizon violates the instability criteria. In this paper, four control modes are designed to meet the control requirements under different operating conditions, namely: yaw control, roll control, yaw-roll integrated control, and no control, as specified in
Table 4. The weighting coefficients in the cost function corresponding to these four different control modes are different, thereby achieving optimal control with respect to several specific objectives. For the convenience of explaining these four different control modes, the left-hand sides of Inequality (13) and Inequality (15) are defined as
YI (
Yaw Index) and
RI (
Roll Index), respectively, i.e.,
YI ≤
c1 and
RI ≤ 1.
YI ≥ c1 && RI < 1 indicates that there is no rollover risk at this moment, but the yaw rate deviates excessively from the desired value, necessitating the intervention of the yaw control mode; YI < c1 && RI ≥ 1 indicates a significant rollover risk, triggering the roll control mode, which primarily aims to reduce the vehicle’s rollover risk while also accommodating the driver’s braking demand. When both YI ≥ c1 and RI ≥ 1 are satisfied, both the yaw control mode and the roll control mode are required to intervene simultaneously. The no-control mode indicates that the vehicle is in a stable state, where only the driver’s acceleration and braking demands are considered, and no intervention from the yaw or roll control modes is needed.
Where Wβ, Wω, WLTR, and WFx = [WFxfl WFxfr WFxrl WFxrr] are the weighting coefficients for the vehicle sideslip angle, yaw rate, and the four tire longitudinal forces, respectively, with the specific values: Wβ = 0.2, Wω = 20, WLTR = |LTR − 0.6|/0.2, WFxfl = WFxfr = WFxrl = WFxrr = 10−4.
In addition to providing the weighting coefficients under different control modes, the decision-making layer also inputs the target reference values within the prediction horizon to the MPC upper-level controller. The target reference values include yaw rate, sideslip angle, and lateral load transfer ratio (
LTR). The yaw rate and sideslip angle are selected as the steady-state values from the ideal two-degree-of-freedom model, which are expressed as follows:
where
K is the vehicle stability factor;
l is the distance between the front and rear axles;
μ is the road adhesion coefficient; and
kf and
kr are the front and rear tire cornering stiffnesses, respectively.
To better limit vehicle sideslip and maintain consistency of the driving direction, βd is taken as zero in this paper. When LTR is less than 1, both sides of the wheels remain in contact with the ground, and the vehicle is considered to be within the safe region of roll. When LTR takes a positive value, a smaller target lateral load transfer ratio is preferable; therefore, the target LTR is set to zero in this paper.
3.5. Design of the Upper-Level MPC Controller
The upper-level controller is based on model predictive control (MPC) theory, which achieves optimal control under constraints through a cost function composed of target reference values and control inputs. It mainly includes three parts: establishment of the prediction model, determination of constraint conditions, and design of the cost function.
3.5.1. Prediction Model
To achieve control in the longitudinal, lateral, yaw, and roll directions, a nonlinear vehicle model is established by combining the vehicle dynamics Equations (1)–(4), as shown in Equation (17). The state-space equation is given in Equation (18):
where the state variable is
, the control variable is
, the control output variable is
.
The nonlinear model contains tire lateral forces, which are the main source of nonlinearity. To simplify the control model, the tire lateral forces in the nonlinear model are replaced by a linear model:
where
Fyf and
Fyr are the total lateral forces of the front and rear axles, respectively; and
αf and
αr are the front and rear tire slip angles, respectively. Substituting Equation (19) into Equation (17), and simultaneously, in order to improve the real-time performance of the control algorithm, a linear time-varying model predictive control is adopted, and the state equation is linearized. Since the model predictive control in this paper adopts a discrete-time control method, the state equation also needs to be discretized. The resulting state equation is given as follows:
where the system matrix
A and control matrix
B are listed in
Appendix A.
Based on the above formulation, the linearization and discretization procedures adopted in this section are as follows. The linearization is performed at the current sampling instant with respect to the current state and input, i.e., a continuous linearization strategy is adopted. At each sampling instant, the Jacobian matrices A and B are computed based on the current states and inputs to ensure that the linearized model consistently tracks the actual state trajectory. For discretization, the forward Euler method is employed with a step size of T = 0.001 s.
It should be noted that, in the current simulation study, the control algorithm is implemented in the MATLAB/Simulink2021b environment, with an average computation time of approximately 2.3 ms per step and a worst-case value of 4.8 ms per step. Although there remains a gap compared with the adopted sampling time of 1 ms, the present study primarily focuses on the validation of the control algorithm at the methodological level. The current implementation is carried out in an offline simulation setting and has not yet been deployed or tested on an embedded real-time platform.
3.5.2. Constraints
To achieve roll stability of the vehicle under high-speed emergency steering conditions, the approximate vertical load coefficient
LTR is constrained. The specific constraint equation is given as follows:
where
.
Meanwhile, in the control process, in order to avoid the control variables computed by the controller exceeding the maximum torque that the in-wheel motors can generate, constraints on the control variables are also required. The control variable constraint expression is given as follows:
where
umin = [Fxflmin Fxfrmin Fxrlmin Fxrrmin]T,
umax = [Fxflmax Fxfrmax Fxrlmax Fxrrmax]T,
∆umin = [∆Fxflmin ∆Fxfrmin ∆Fxrlmin ∆Fxrrmin]T,
∆umax = [∆Fxflmax ∆Fxfrmax ∆Fxrlmax ∆Fxrrmax]T.
3.5.3. Cost Function Design
In order to satisfy the vehicle’s yaw stability and roll stability, this paper expects the actual yaw rate to closely track the desired yaw rate, while keeping the
LTR value as small as possible. Then the cost function of MPC can be defined as:
where
p is the prediction horizon,
m is the control horizon, with
m ≤
p,
y is the control output,
yd is the reference value, and
λyi and
λui are the weighting factors for the control output and control input at the prediction time
k +
i, respectively. They are defined as:
3.6. Design of the Lower-Level Controller
In this paper, a lower-level torque distribution controller is designed with the tire load ratio as the optimization objective. When tire adhesion reaches the saturation state, the vehicle is highly prone to instability. Therefore, the margin of tire adhesion can characterize the vehicle’s anti-instability capability: the larger the adhesion margin, the less likely the vehicle is to become unstable. Consequently, during yaw moment distribution, ensuring the highest tire utilization rate can reserve as much adhesion margin as possible for the vehicle. Thus, the tire utilization rate is adopted to design the optimization objective.
The tire utilization rate refers to the ratio of the utilized adhesion force of a single wheel to the maximum adhesion force that the ground can provide, and is expressed as:
In this paper, the sum of squares of the four tire utilization rates is selected as the optimization objective function, which can be described as:
Since the motors of distributed-drive electric vehicles can only generate longitudinal tire forces, and the control of tire lateral forces is relatively difficult, the objective function needs to be improved to conform to practical conditions. The improved objective function can be described as:
The upper-level controller computes the desired longitudinal forces for the four wheels, from which the desired additional yaw moment Δ
Mtar required to maintain vehicle stability is then calculated. To ensure normal vehicle operation, the resultant longitudinal forces of the individual wheels must satisfy the total driving force demand of the vehicle, and simultaneously, the yaw moment generated by the differences in wheel longitudinal forces must meet the requirements of stability control. Therefore, the vehicle dynamics must satisfy the following equality constraints:
where
Fx1,
Fx2,
Fx3, and
Fx4 are the tire longitudinal forces of the left-front, right-front, left-rear, and right-rear wheels, respectively, and
Fd is the total driving force of the vehicle.
Since the adhesion force of each wheel must be less than the value that the ground can provide, and the driving force distributed to each wheel cannot exceed the maximum driving force that the in-wheel motor can provide, the vehicle also needs to satisfy the following inequality constraints:
By combining the above equations, the optimal distribution problem of the yaw moment can be expressed as:
It is worth noting that the four tire longitudinal forces computed by the upper-level MPC are not directly applied to the in-wheel motors. In practice, the longitudinal force vector obtained from the upper-level MPC is used to calculate the desired additional yaw moment ΔMtar, which, together with the driver’s total longitudinal force demand Fd, serves as the equality constraints for the lower-level torque allocator. The lower-level allocator then re-solves the individual wheel longitudinal forces by minimizing the tire utilization rate, subject to both the total longitudinal force demand and the desired additional yaw moment constraints. The rationale behind this design lies in the fact that the lower-level allocator preserves the overall vehicle longitudinal and lateral dynamic responses as commanded by the upper-level controller, while further optimizing the force distribution among individual wheels to maximize tire adhesion margins and strictly satisfying actuator constraints such as motor peak torque limits.
4. Simulation Results and Analysis
To verify the effectiveness of the integrated yaw and roll control strategy (YRIC) proposed in this paper, the control algorithm is built on the MATLAB/Simulink2021b platform and co-simulated with CarSim2020. Under low road adhesion coefficient conditions, three simulation scenarios are designed, namely the double lane change maneuver, the sine steering angle input maneuver, and the fishhook steering input maneuver. Comparative simulation analyses are conducted between the uncontrolled case and the integrated yaw and roll control case. In addition, to further validate the effectiveness of the proposed integrated control strategy in terms of vehicle roll control, a direct yaw moment control (DYC) based on MPC is adopted for comparison with the integrated control strategy proposed in this paper. In the MPC, the prediction horizon Np is set to 50, and the control horizon Nc is set to 10. The MATLAB quadprog solver is employed with a maximum iteration count of 100. The linearized model is updated every 5 sampling instants to balance control accuracy and computational burden. When the QP problem becomes infeasible, a soft constraint strategy is adopted, in which the slack variables prioritize the relaxation of the LTR constraint to ensure that a feasible solution can always be output. The parameter settings for the comparison scheme are as follows: DYC adopts the same MPC framework as YRIC, but the roll-related weight coefficients in the cost function are set to zero, while the two yaw-related weight coefficients remain consistent with those of YRIC. The constraint conditions and the lower-level allocation strategy are exactly the same as well.
In the simulation validation of this study, critical state variables including the sideslip angle, sideslip angle rate, and road adhesion coefficient are directly acquired from the CarSim simulation environment and are assumed to be perfectly known, without considering the effects of sensor noise, signal delays, or estimation errors. In practical engineering applications, however, these state quantities must be estimated through onboard sensor fusion or state observers, and the estimation accuracy will inevitably affect the control performance. This constitutes a key issue that needs to be further addressed in the real-world deployment of the proposed strategy.
4.1. Double Lane Change Maneuver
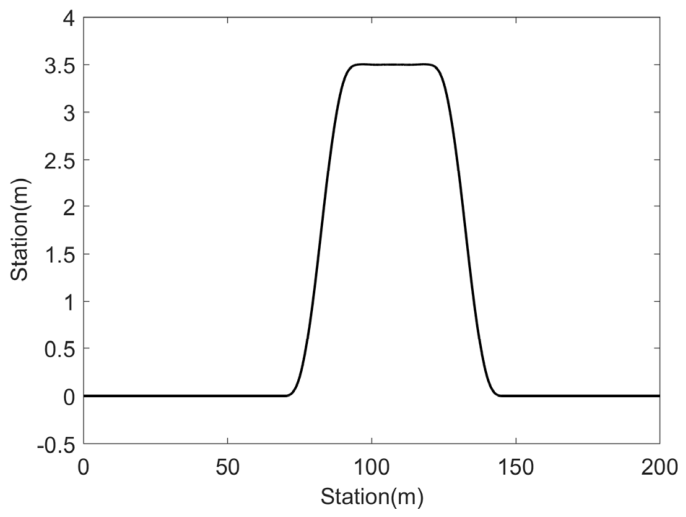
The double lane change maneuver is adopted to simulate emergency obstacle avoidance or overtaking conditions of a distributed-drive electric vehicle traveling at high speed on a low-adhesion road. In Carsim, the desired vehicle speed is set to 80 km/h, the road adhesion coefficient is set to 0.6, and the expected trajectory is shown in
Figure 13.
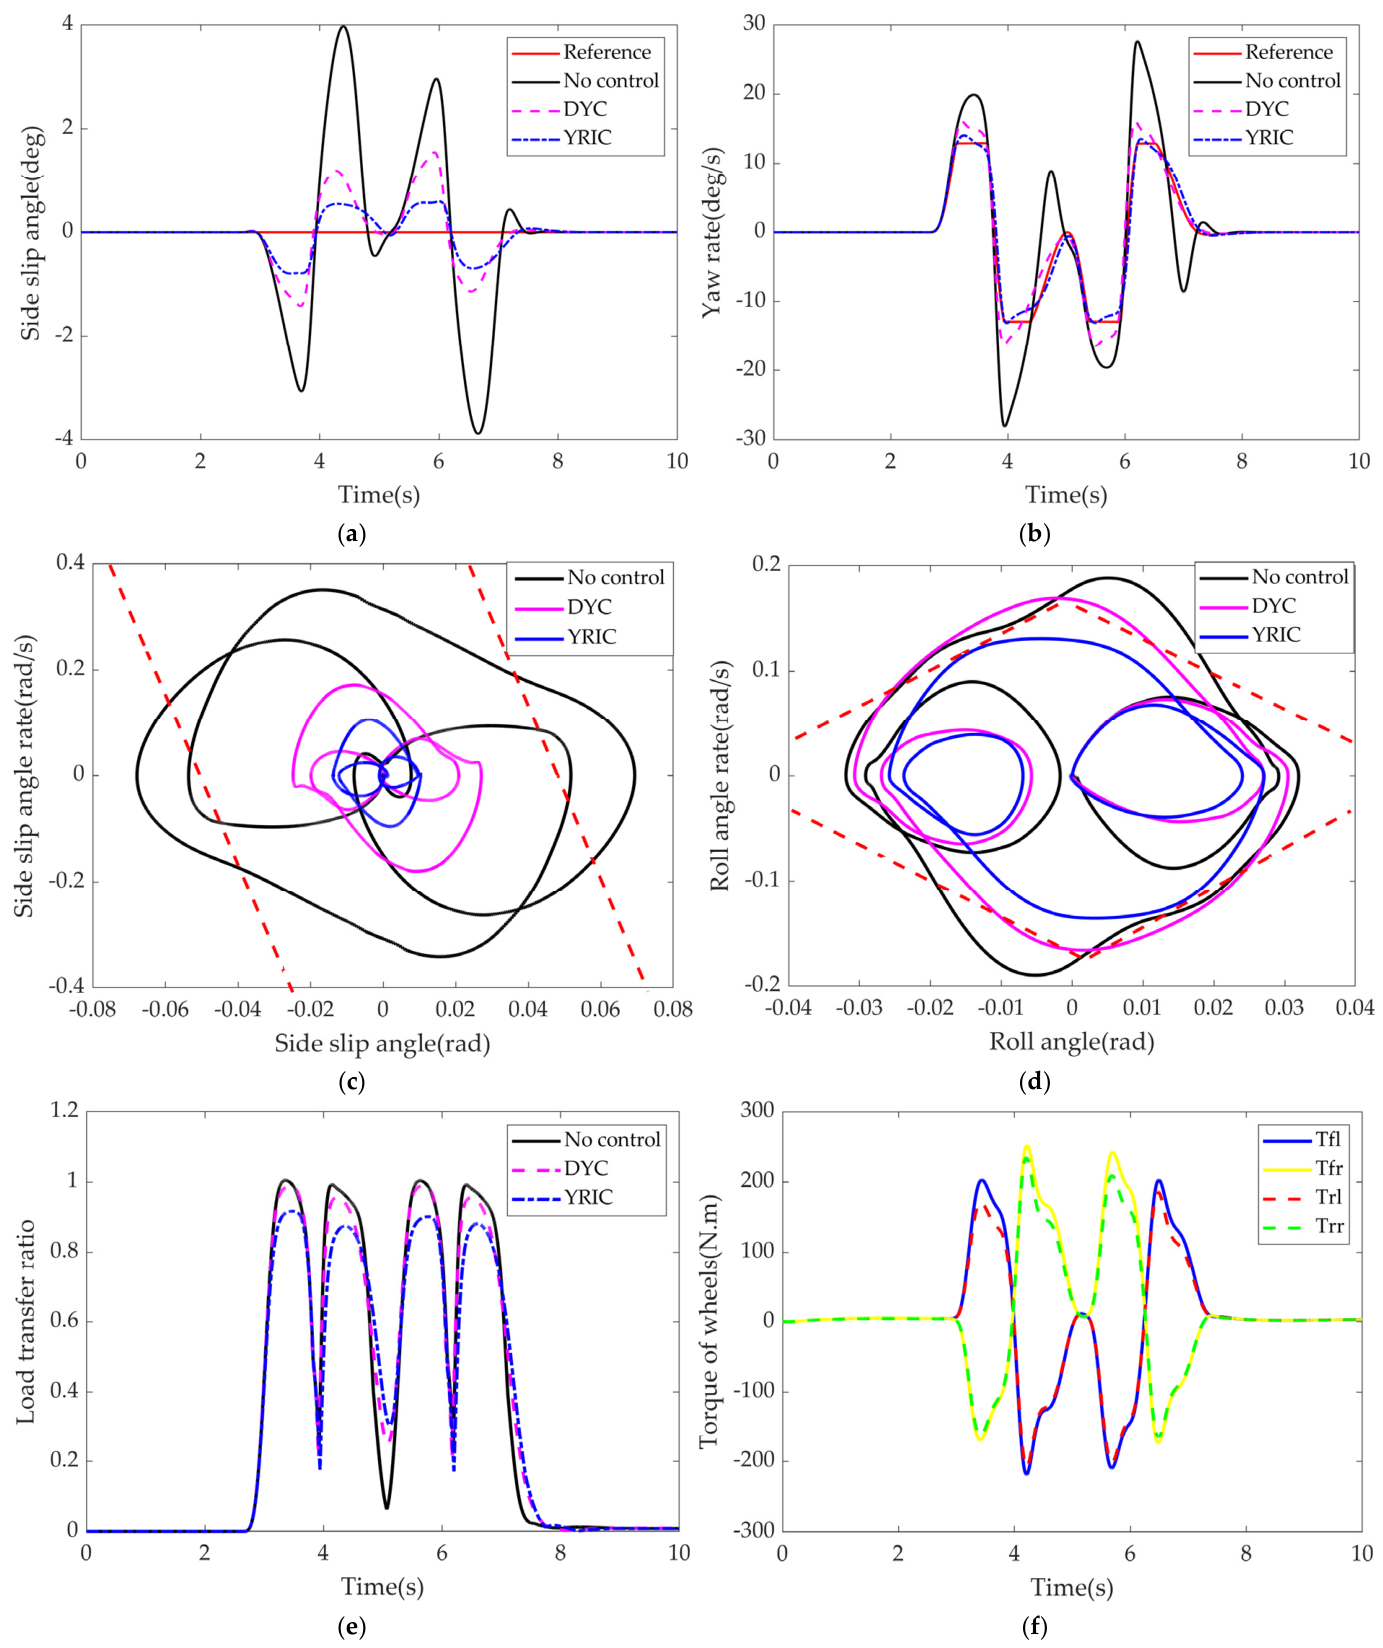
As shown in
Figure 14a, at 4.4 s, the sideslip angle under uncontrolled conditions reaches its maximum amplitude of 4 deg. In contrast, under the DYC and YRIC schemes, the sideslip angles are significantly reduced, reaching their maximum amplitudes at 5.9 s and 3.5 s, respectively, with values of 1.5 deg and 0.8 deg. Compared with the DYC scheme, the sideslip angle under the YRIC scheme is reduced by 46.7%. Similarly, as analyzed in
Figure 14b, at 3.9 s, the yaw rate under uncontrolled conditions reaches its maximum amplitude of 28.1 deg/s. At 5.5 s and 3.3 s, the yaw rates under DYC and YRIC reach their maximum amplitudes, with values of 16.5 deg/s and 14.1 deg/s, respectively. Compared with the DYC scheme, the YRIC scheme reduces the yaw rate by 14.5%.
Observing the
phase trajectory diagram and the
phase trajectory diagram of the vehicle, as shown in
Figure 14c and
Figure 14d, respectively. The
phase trajectory diagram shows that under YRIC, the vehicle’s sideslip angle and sideslip angular velocity remain within the stability boundaries, indicating good yaw stability. Similarly, the
phase trajectory diagram shows that under YRIC, the vehicle’s roll angle and roll angular velocity also remain within the stability boundaries, indicating good roll stability. The lateral load transfer ratio of the vehicle under the double lane change maneuver is shown in
Figure 14e. Under uncontrolled conditions, the LTR is close to 1, indicating that the vehicle is approaching instability and is prone to rollover. Under DYC, the LTR is similar to that under uncontrolled conditions, while under YRIC, the LTR is reduced to some extent. Under YRIC control, the wheel torques are shown in
Figure 14f, and the wheel torques remain below the peak torque of the motor throughout.
The above conditions are only simulations conducted under high-speed and low-adhesion conditions. To verify the practicability of the controller designed in this paper under other vehicle speeds and road adhesion conditions, this section sets up four cases to compare the no-control, DYC, and YRIC schemes in terms of the RMS of sideslip angle, the RMS of yaw rate, the RMS error of yaw rate with respect to the desired value, and the maximum LTR. Case 1 sets the vehicle speed to 60 km/h and the road adhesion coefficient to 0.6. Case 2 sets the vehicle speed to 60 km/h and the road adhesion coefficient to 0.85. Case 3 sets the vehicle speed to 80 km/h and the road adhesion coefficient to 0.6. Case 4 sets the vehicle speed to 80 km/h and the road adhesion coefficient to 0.85. The data for each case are shown in
Table 5, where the three values in each cell represent the no-control, DYC, and YRIC schemes, respectively.
Meanwhile, a numerical verification of the force and yaw moment equality constraints was conducted under the double lane change maneuver, which represents the most severe operating condition. The results show that the root mean square (RMS) deviation of the total longitudinal force constraint is 17.63 N, and the RMS deviation of the additional yaw moment constraint is 11.52 N·m.
4.2. Sine Steering Angle Input Maneuver
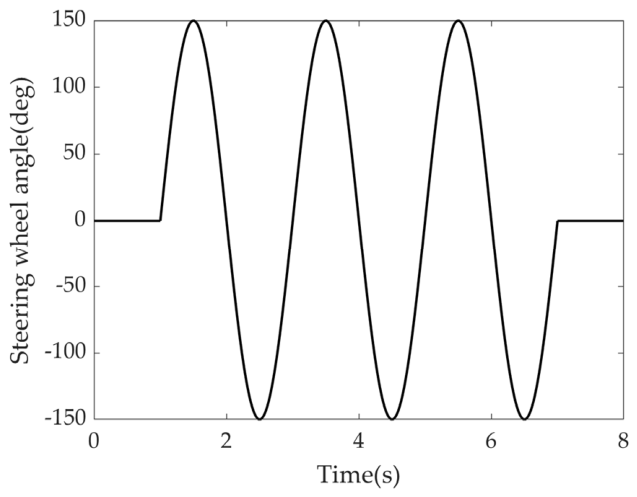
To further verify the applicability of the integrated yaw and roll control strategy (YRIC) under other operating conditions, a sine steering angle input maneuver is designed to simulate the continuous large-angle steering of a distributed-drive electric vehicle, so as to verify the vehicle’s dynamic lateral stability and roll stability. The vehicle speed is set to 80 km/h, and the steering wheel angle adopts a sinusoidal input with a period of 2 s and an amplitude of 150 deg. The steering wheel input is shown in
Figure 15.
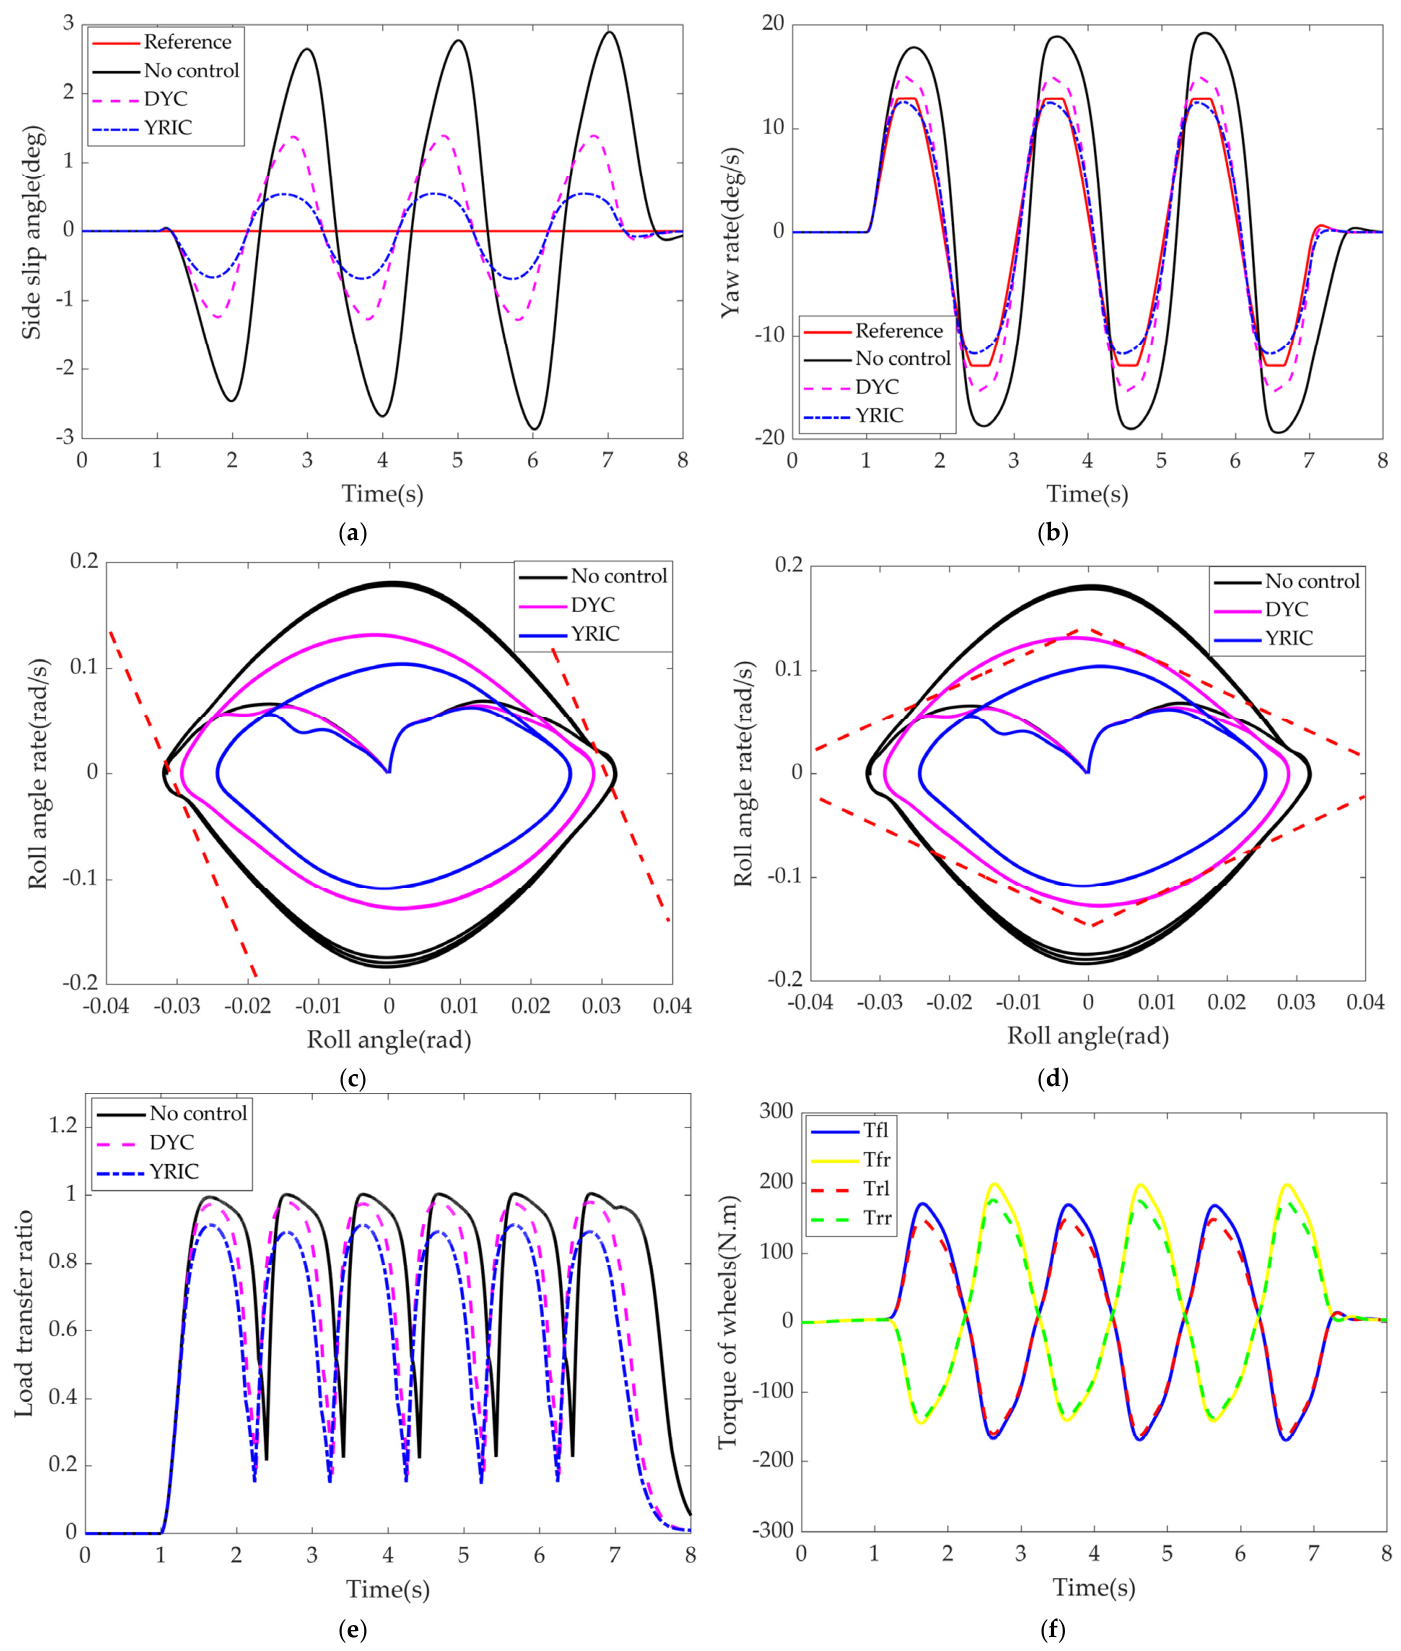
As shown in
Figure 16a, at 7.0 s, the sideslip angle under uncontrolled conditions reaches its maximum amplitude of 2.9 deg. In contrast, under the DYC and YRIC schemes, the sideslip angles are significantly reduced, reaching their maximum amplitudes at 2.8 s and 1.8 s, respectively, with values of 1.4 deg and 0.7 deg. Compared with the DYC scheme, the sideslip angle under the YRIC scheme is reduced by 50%. Similarly, as analyzed in
Figure 16b, at 6.6 s, the yaw rate under uncontrolled conditions reaches its maximum amplitude of 19.4 deg/s. At 2.5 s and 1.5 s, the yaw rates under DYC and YRIC reach their maximum amplitudes, with values of 15.3 deg/s and 12.6 deg/s, respectively. Compared with the DYC scheme, the YRIC scheme reduces the yaw rate by 17.6%.
By the same approach, the
phase trajectory diagram and the
phase trajectory diagram of the vehicle are observed, as shown in
Figure 16c and
Figure 16d, respectively. The
phase trajectory diagram shows that under YRIC, the vehicle’s sideslip angle and sideslip angular velocity remain within the stability boundaries. Similarly, the
phase trajectory diagram shows that under YRIC, the vehicle’s roll angle and roll angular velocity also remain within the stability boundaries. The lateral load transfer ratio of the vehicle under the sine steering angle input maneuver is shown in
Figure 16e. Under uncontrolled conditions, the LTR nearly approaches 1, indicating a high risk of vehicle rollover. Under DYC, the LTR also remains close to 1, while under YRIC, the LTR is considerably reduced. Under YRIC control, the wheel torques are shown in
Figure 16f, and the wheel torques remain below the peak torque of the motor throughout.
Similarly, the comparison of control performance under the sinusoidal steering input maneuver is shown in
Table 6.
4.3. Fishhook Steering Input Maneuver
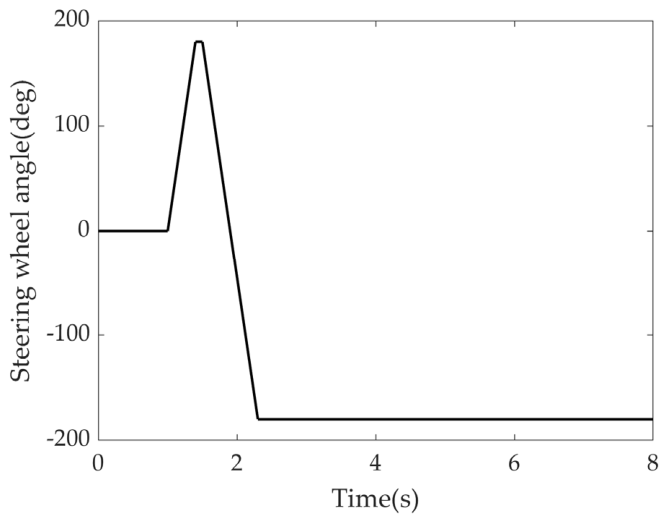
To verify the anti-rollover capability of the vehicle under the integrated yaw and roll control (YRIC), a fishhook steering input maneuver is designed to simulate the situation of a distributed-drive electric vehicle traveling at high speed with abrupt steering wheel operation, so as to verify the vehicle’s roll stability. The steering wheel input is shown in
Figure 17.
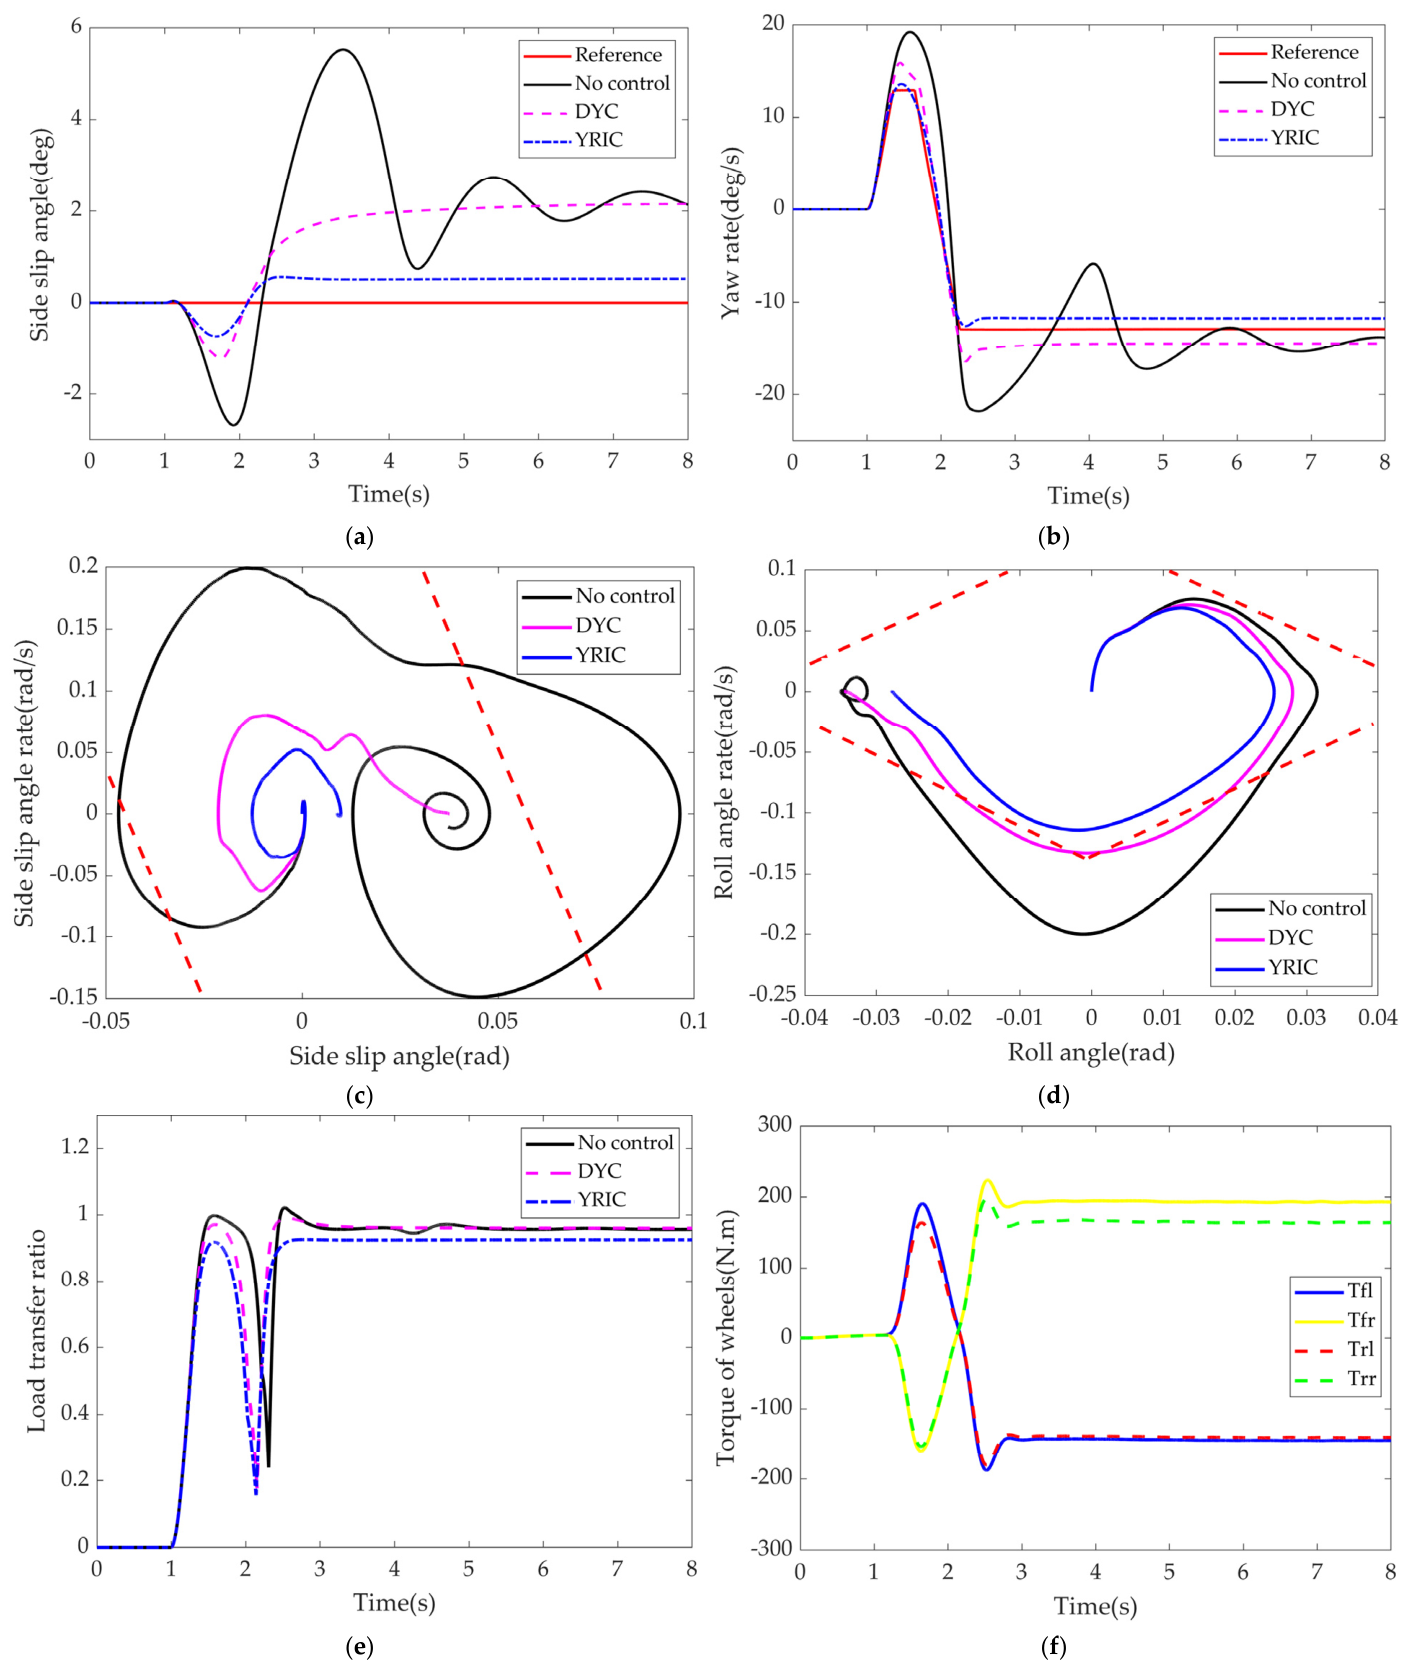
As shown in
Figure 18a, at 3.4 s, the sideslip angle under uncontrolled condition reaches its maximum amplitude of 5.5 deg. In contrast, under the DYC and YRIC schemes, the sideslip angles are significantly reduced, reaching their maximum amplitudes at 8.0 s and 1.7 s, respectively, with values of 2.2 deg and 0.7 deg. Compared with the DYC scheme, the sideslip angle under the YRIC scheme is reduced by 68.2%. Similarly, as analyzed in
Figure 18b, at 2.5 s, the yaw rate under uncontrolled condition reaches its maximum amplitude of 21.8 deg/s. At 2.3 s and 1.5 s, the yaw rates under DYC and YRIC reach their maximum amplitudes, with values of 16.4 deg/s and 13.6 deg/s, respectively. Compared with the DYC scheme, the YRIC scheme reduces the yaw rate by 17.1%.
Observing the
phase trajectory diagram and the
phase trajectory diagram of the vehicle, as shown in
Figure 18c and
Figure 18d, respectively. The
phase trajectory diagram shows that under YRIC, the vehicle’s sideslip angle and sideslip angular velocity remain within the stability boundaries. Similarly, the
phase trajectory diagram shows that under YRIC, the vehicle’s roll angle and roll angular velocity also remain within the stability boundaries. The lateral load transfer ratio of the vehicle under the fishhook steering input maneuver is shown in
Figure 18e. Under YRIC, the LTR is significantly reduced, indicating that the vehicle’s roll attitude can be corrected to a certain extent. Under YRIC control, the wheel torques are shown in
Figure 18f, and the wheel torques remain below the peak torque of the motor throughout.
Similarly, the comparison of control performance under the fishhook steering input maneuver is shown in
Table 7.
From the simulation results of the above three maneuvers, it can be seen that the MPC-based YRIC method can accurately track the desired values of sideslip angle and yaw rate, while also maintaining the vehicle’s lateral load transfer ratio within a stable range. Furthermore, from the data in the control performance comparison tables under the three maneuver types, it is evident that the integrated controller designed in this paper can adapt to a wide range of operating conditions with significant control effectiveness. Under all tested simulation conditions, the vehicle states can be maintained within the stable region, while simultaneously ensuring both yaw stability and roll stability.


 ,