1. Introduction
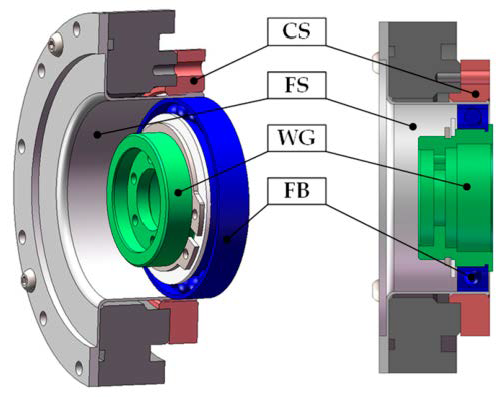
The harmonic drive is a precision transmission device that utilizes the controllable elastic deformation of flexible components to transmit motion and power. Its main structure consists of a circular spline (CS), a flexspline (FS), a wave generator (WG), and a flexible bearing (FB) (as shown in
Figure 1) [
1,
2,
3]. With this structural configuration, the harmonic drive offers distinct advantages in engineering practice, including large transmission ratios, high torque density, and high transmission accuracy, alongside smooth operation and low noise. These excellent attributes render it a core component in high-precision servo drives, making it widely applied in cutting-edge equipment such as industrial robots, humanoid robot joint drives, and aerospace spaceborne mechanisms [
4,
5,
6]. As the core transmission component of these precision systems, the dynamic transmission performance of the harmonic drive directly determines the end-effector trajectory accuracy and service reliability of the entire system.
Extensive research has investigated the factors influencing harmonic drive transmission errors. Internal geometric manufacturing defects and structural assembly misalignments are generally considered the underlying deterministic causes, mainly manifesting as static or quasi-static accuracy deviations during operation [
7,
8,
9]. With advancements in digital simulation and precision testing, the quantitative characterization of these errors has been significantly enriched. For instance, Yang et al. [
10] achieved fine regulation of the meshing backlash by constructing a time-varying backlash model combined with radial deformation compensation, while Song et al. [
11] developed a spatial conjugate tooth surface design framework for double-circular-arc profiles. Kim et al. [
12] integrated non-contact measurement with 3D meshing models to accurately predict angular transmission errors. To quantify the physical modulation of these geometric deviations, Dong et al. [
13] equivalently modeled the single-tooth meshing process of the FS and CS as a spatial gear-linkage mechanism, and Zheng et al. [
14] constructed a kinematic model considering multi-tooth contact status and torque. Furthermore, Jia et al. [
15] isolated non-uniform motion and hysteresis components to explore the modulation laws of multiple structural parameters, and Yang et al. [
16] integrated manufacturing defects, misalignments, and wear degradation to establish a comprehensive full-lifecycle error prediction model.
While static analyses effectively quantify inherent system deviations, actual transmission error fluctuations are profoundly modulated by dynamic excitations (e.g., load and rotational speed) and internal dynamic parameters like stiffness and frictional damping [
17,
18,
19]. Consequently, establishing high-precision dynamic models is crucial for performance prediction. In this regard, Chen et al. [
20] introduced measured pitch deviations into a dynamics framework to analyze bifurcation behaviors and reveal stability modulation mechanisms. Zhao et al. [
21] established a dynamic model considering accumulated pitch deviations to predict geometric transmission error (GTE) characteristics, identifying the relationship between its beat frequency and component amplitude differences. To accurately reproduce actual responses, Guida et al. [
22] proposed a high-fidelity analytical model comprehensively capturing kinematic errors, non-linear hysteresis, internal friction, and meshing effects. Additionally, Folęga et al. [
23] focused on non-linear stiffness variations and damping to address model inaccuracies in torsional vibration analysis, while Zhang et al. [
24] achieved a fine characterization of hysteresis loss by establishing compliance models for specific components. Hei et al. [
25] further developed a modeling method featuring low-frequency resonance, and Hu et al. [
26] confirmed the strong coupling among non-linear torsional stiffness, transmission error, and meshing damping during transient processes, demonstrating that increased errors can significantly exacerbate system vibrations and induce instability.
Although previous studies have thoroughly investigated transmission errors from the aforementioned geometric and dynamic perspectives, existing models generally rely on the idealized assumption of entirely deterministic structural parameters. However, in engineering practice, geometric transmission errors, as well as the stiffness and damping coefficients determining dynamic responses, exhibit random or interval fluctuations within specific ranges due to manufacturing tolerances and variable operating conditions. These constitute typical uncertain parameters. Since existing deterministic models fail to adequately account for the fluctuation characteristics of these multi-source uncertainties, they struggle to accurately reveal their comprehensive impact mechanisms on the dynamic transmission error (DTE). Consequently, establishing a DTE model for harmonic drives under the influence of multi-source uncertain parameters is crucial for a realistic representation of the system’s dynamic precision behavior under actual operating conditions.
As a core indicator characterizing the dynamic accuracy of a transmission system, the time-domain response of the DTE is not a simple static algebraic mapping. To accurately obtain this response, physical mechanisms such as the torsion and meshing deformation of internal components must be comprehensively considered to establish dynamic differential equations, which are then solved via numerical integration [
27,
28,
29]. However, under actual working conditions, subjected to the joint disturbance of multi-source uncertain parameters, the dynamic evaluation of harmonic drives must shift from conventional deterministic solutions to uncertainty analysis within a probabilistic space. In this context, if traditional time integration methods, such as Runge–Kutta or Newmark-
β, are directly adopted in combination with Monte Carlo (MC) sampling to solve massive uncertain samples sequentially, the computational cost will increase exponentially. Particularly, considering the coupling effects of physical characteristics such as the large deformation of the FS, time-varying meshing stiffness, and friction, the uncertain parameters and the DTE response exhibit an implicit mapping relationship lacking an analytical solution. Under this evaluation mode of “numerical integration coupled with large-sample sampling,” the enormous computational load will become the core efficiency bottleneck for subsequent high-frequency iterations and robust design.
To reduce the repetitive evaluation costs of complex dynamic equations, introducing surrogate models to establish an explicit mapping between uncertain parameters and dynamic responses has become a prominent trend [
30,
31]. However, when dealing with DTE responses, traditional surrogate models often struggle to balance approximation accuracy and numerical stability. Low-order models fail to accurately characterize complex nonlinear mappings, whereas simply increasing the polynomial order is highly prone to triggering the Runge phenomenon, leading to fitting distortions. In contrast, Chebyshev polynomials possess excellent orthogonality and near-minimax uniform approximation capabilities. They can effectively suppress the numerical oscillations associated with high-order polynomials, significantly enhancing the computational stability of the model across the entire uncertainty interval [
32,
33,
34]. Therefore, constructing a high-precision surrogate model using Chebyshev polynomials is an effective approach to efficiently obtain the statistical characteristics of DTE and overcome the efficiency bottleneck of large-sample evaluations.
It should be noted that achieving high-precision response prediction for DTE is merely the foundation. To meet the high-performance requirements of harmonic drives under complex operating conditions, it is necessary to further implement robust multi-objective optimization for DTE [
35,
36]. However, significant trade-offs often exist among multiple performance objectives of the drive, and the corresponding multi-objective mapping space exhibits characteristics of high coupling, non-convexity, and local sensitivity. Traditional intelligent optimization algorithms (such as the multi-objective particle swarm optimization, MOPSO) mostly rely on fixed parameters or iteration-based open-loop evolution strategies for their inertia weight and velocity update mechanisms when dealing with such complex constrained spaces, lacking real-time perception of population diversity and search stagnation states. As a result, particles are prone to premature convergence under the traction of complex objective surfaces, causing the algorithm to fall into local optima [
37,
38]. Therefore, state-aware improvements to traditional algorithms are urgently needed. By introducing population diversity feedback to dynamically adjust search behavior, supplemented by a multi-layer architecture solution set maintenance strategy, the algorithm’s ability to escape local traps and conduct global optimization can be significantly enhanced.
In light of this, this paper proposes a robust multi-objective optimization method for DTE that integrates a Chebyshev surrogate model with an adaptive multi-layer pyramid multi-objective particle swarm optimization (AMP-MOPSO) algorithm. This method utilizes the Chebyshev surrogate model to effectively eliminate the repetitive computational costs of complex dynamic equations. Furthermore, relying on the state-aware AMP-MOPSO algorithm, it efficiently achieves the global robust optimization of the harmonic drive’s DTE under multi-source parameter uncertainties.
The remainder of this paper is organized as follows:
Section 2 presents the Chebyshev surrogate modeling of the harmonic drive’s DTE considering parameter uncertainties;
Section 3 details the dynamic parameter identification and DTE case calculations;
Section 4 conducts the experimental validation of the Chebyshev surrogate model;
Section 5 performs the robust multi-objective optimization of DTE based on the Chebyshev–AMP–MOPSO algorithm;
Section 6 summarizes the main conclusions of this study.
2. Chebyshev Surrogate Modeling of Harmonic Drive DTE Under Parameter Uncertainty
The DTE of harmonic drives is jointly influenced by the uncertainties in the static transmission error (STE) and the dynamic parameters. This study proposes a novel multi-source uncertainty analysis method for DTE. First, a probabilistic model of STE is constructed via MC simulation based on measured statistical parameters of error sources. Subsequently, a mathematical model of DTE is formulated using differential dynamic equations. Following this, an efficient surrogate model is established by introducing the Chebyshev polynomial approach. Finally, statistical characteristics of DTE are obtained through MC sampling. The proposed method provides an effective means for DTE evaluation and uncertainty quantification of harmonic drives.
2.1. STE Modeling Based on Probability Distribution
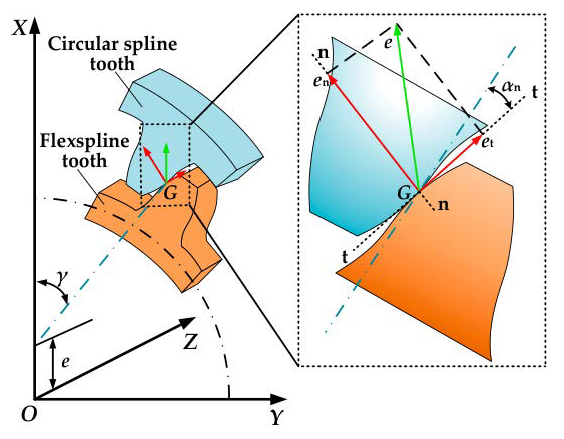
The STE of a harmonic drive originates from the spatial vector synthesis of system geometric errors during the kinematic transmission process. The manufacturing and assembly errors of core components such as the FS, CS, and WG constitute the initial error sources of the system. Such errors mainly evolve into geometric eccentricity and kinematic eccentricity during transmission, manifesting physically as the spatial position deviation between the theoretical meshing point and the actual meshing position.
As shown in
Figure 2, taking the FS as an example, its geometric eccentricity error
e at the meshing point
G can be decomposed into a tangential component
et and a normal component
en. Specifically,
en =
e sin(
γ +
αn) (where
γ is the meshing phase angle, and
αn is the pitch circle pressure angle of the FS) directly leads to transmission error, whereas
et only affects the tooth surface contact characteristics. This decomposition characteristic reveals the vector superposition mechanism of STE.
This paper selects the HS-20-100 model harmonic drive as the research object. The initial error sources of its main components and the motion errors generated by each eccentricity error are listed in
Table 1.
In the table, ejk represents the eccentricity error; φjk is the initial phase angle of the corresponding eccentricity error; ω is the rotational angular velocity of the WG; t is the time parameter; Zf is the number of teeth of the FS, taken as 200; and Zc is the number of teeth of the CS, taken as 202.
Based on the periodic characteristics of the errors, the motion errors in
Table 1 can be systematically categorized into the following four major classes: (1) stationary eccentricity errors (
em and
ep) that generate motion errors with a frequency of 2
ω; (2) eccentricity errors rotating with the FS (
eg) that generate motion errors with a frequency of 2
Zc/
Zfω; (3) eccentricity errors rotating with the WG (
ew) that generate motion errors with a frequency of
ω; and (4) small-period errors formed by the machining errors of the CS and FS (
eh) that generate motion errors with a frequency of 2
Zcω.
Therefore, the total motion error of the harmonic drive can be expressed as
where
φm,
φg,
φw,
φp and
φh are the initial phase angles of the corresponding eccentricity error vectors.
Considering the error averaging effect of multi-tooth meshing, the modified STE formula of the harmonic drive can be expressed as
where
Kb is the influence coefficient of multi-tooth meshing transmission error, taken as 0.9;
zt is the number of teeth simultaneously engaged in meshing, taken as 50, and
d is the pitch circle diameter of the CS, taken as 51.348 mm.
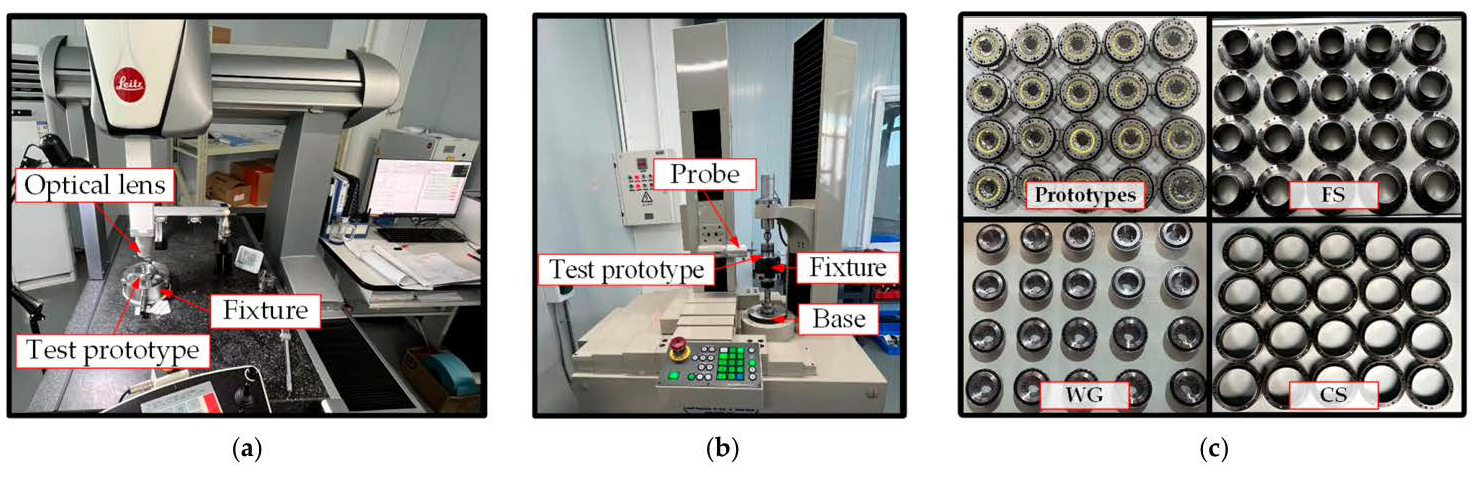
Twenty prototype harmonic drives of the same model were selected for eccentricity error measurement experiments. A coordinate measuring machine (with an accuracy of 0.3 μm) was employed to obtain the manufacturing and assembly error data (see
Figure 3a), while a gear measuring center (with an accuracy of 1 μm/m) was utilized to extract the tooth profile errors (see
Figure 3b). Each prototype was measured 10 times. Based on the normal distribution assumption of the random noise from the measuring instruments, the 3σ criterion was applied to eliminate abnormal measurements, and the arithmetic mean of the valid data was taken as the representative value of the actual error.
To verify the statistical distribution characteristics of the errors, the Shapiro–Wilk (S-W) normality test was performed on the measurement data. As shown in
Table 2, the
W statistics of the 13 error indicators range from 0.987 to 0.995, and the corresponding
p-values (ranging from 0.064 to 0.722) are all greater than the significance level of 0.05. Since all
p-values exceed 0.05, the null hypothesis of normality cannot be rejected for the present samples. Therefore, normal distributions are adopted as reasonable probabilistic approximations for the subsequent analysis. Accordingly, the statistical mean
μ and standard deviation
σ of each error indicator were extracted (see
Table 2) as input parameters for the subsequent surrogate modeling.
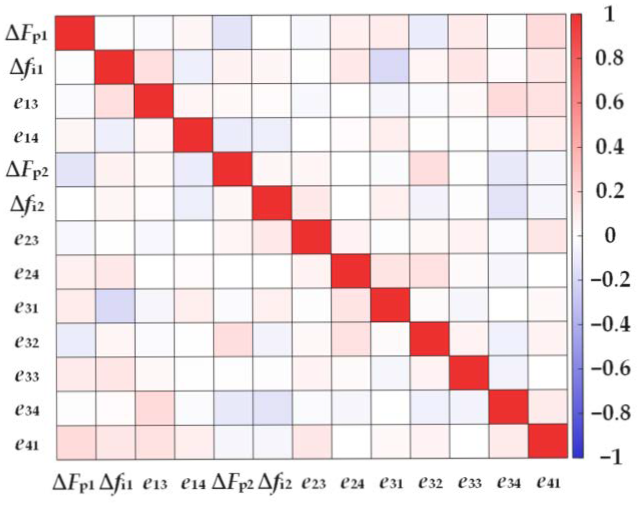
Based on the above normality test results, the Pearson correlation coefficients of the 13 error indicators were further calculated to examine their statistical independence. As shown in the heatmap of the correlation coefficient matrix in
Figure 4, the absolute values of the off-diagonal elements are generally low, exhibiting no significant linear correlation characteristics. The generally weak Pearson correlations indicate no pronounced linear dependence among the measured error indicators. Accordingly, approximate independence is adopted as a modeling assumption for the subsequent Monte Carlo analysis.
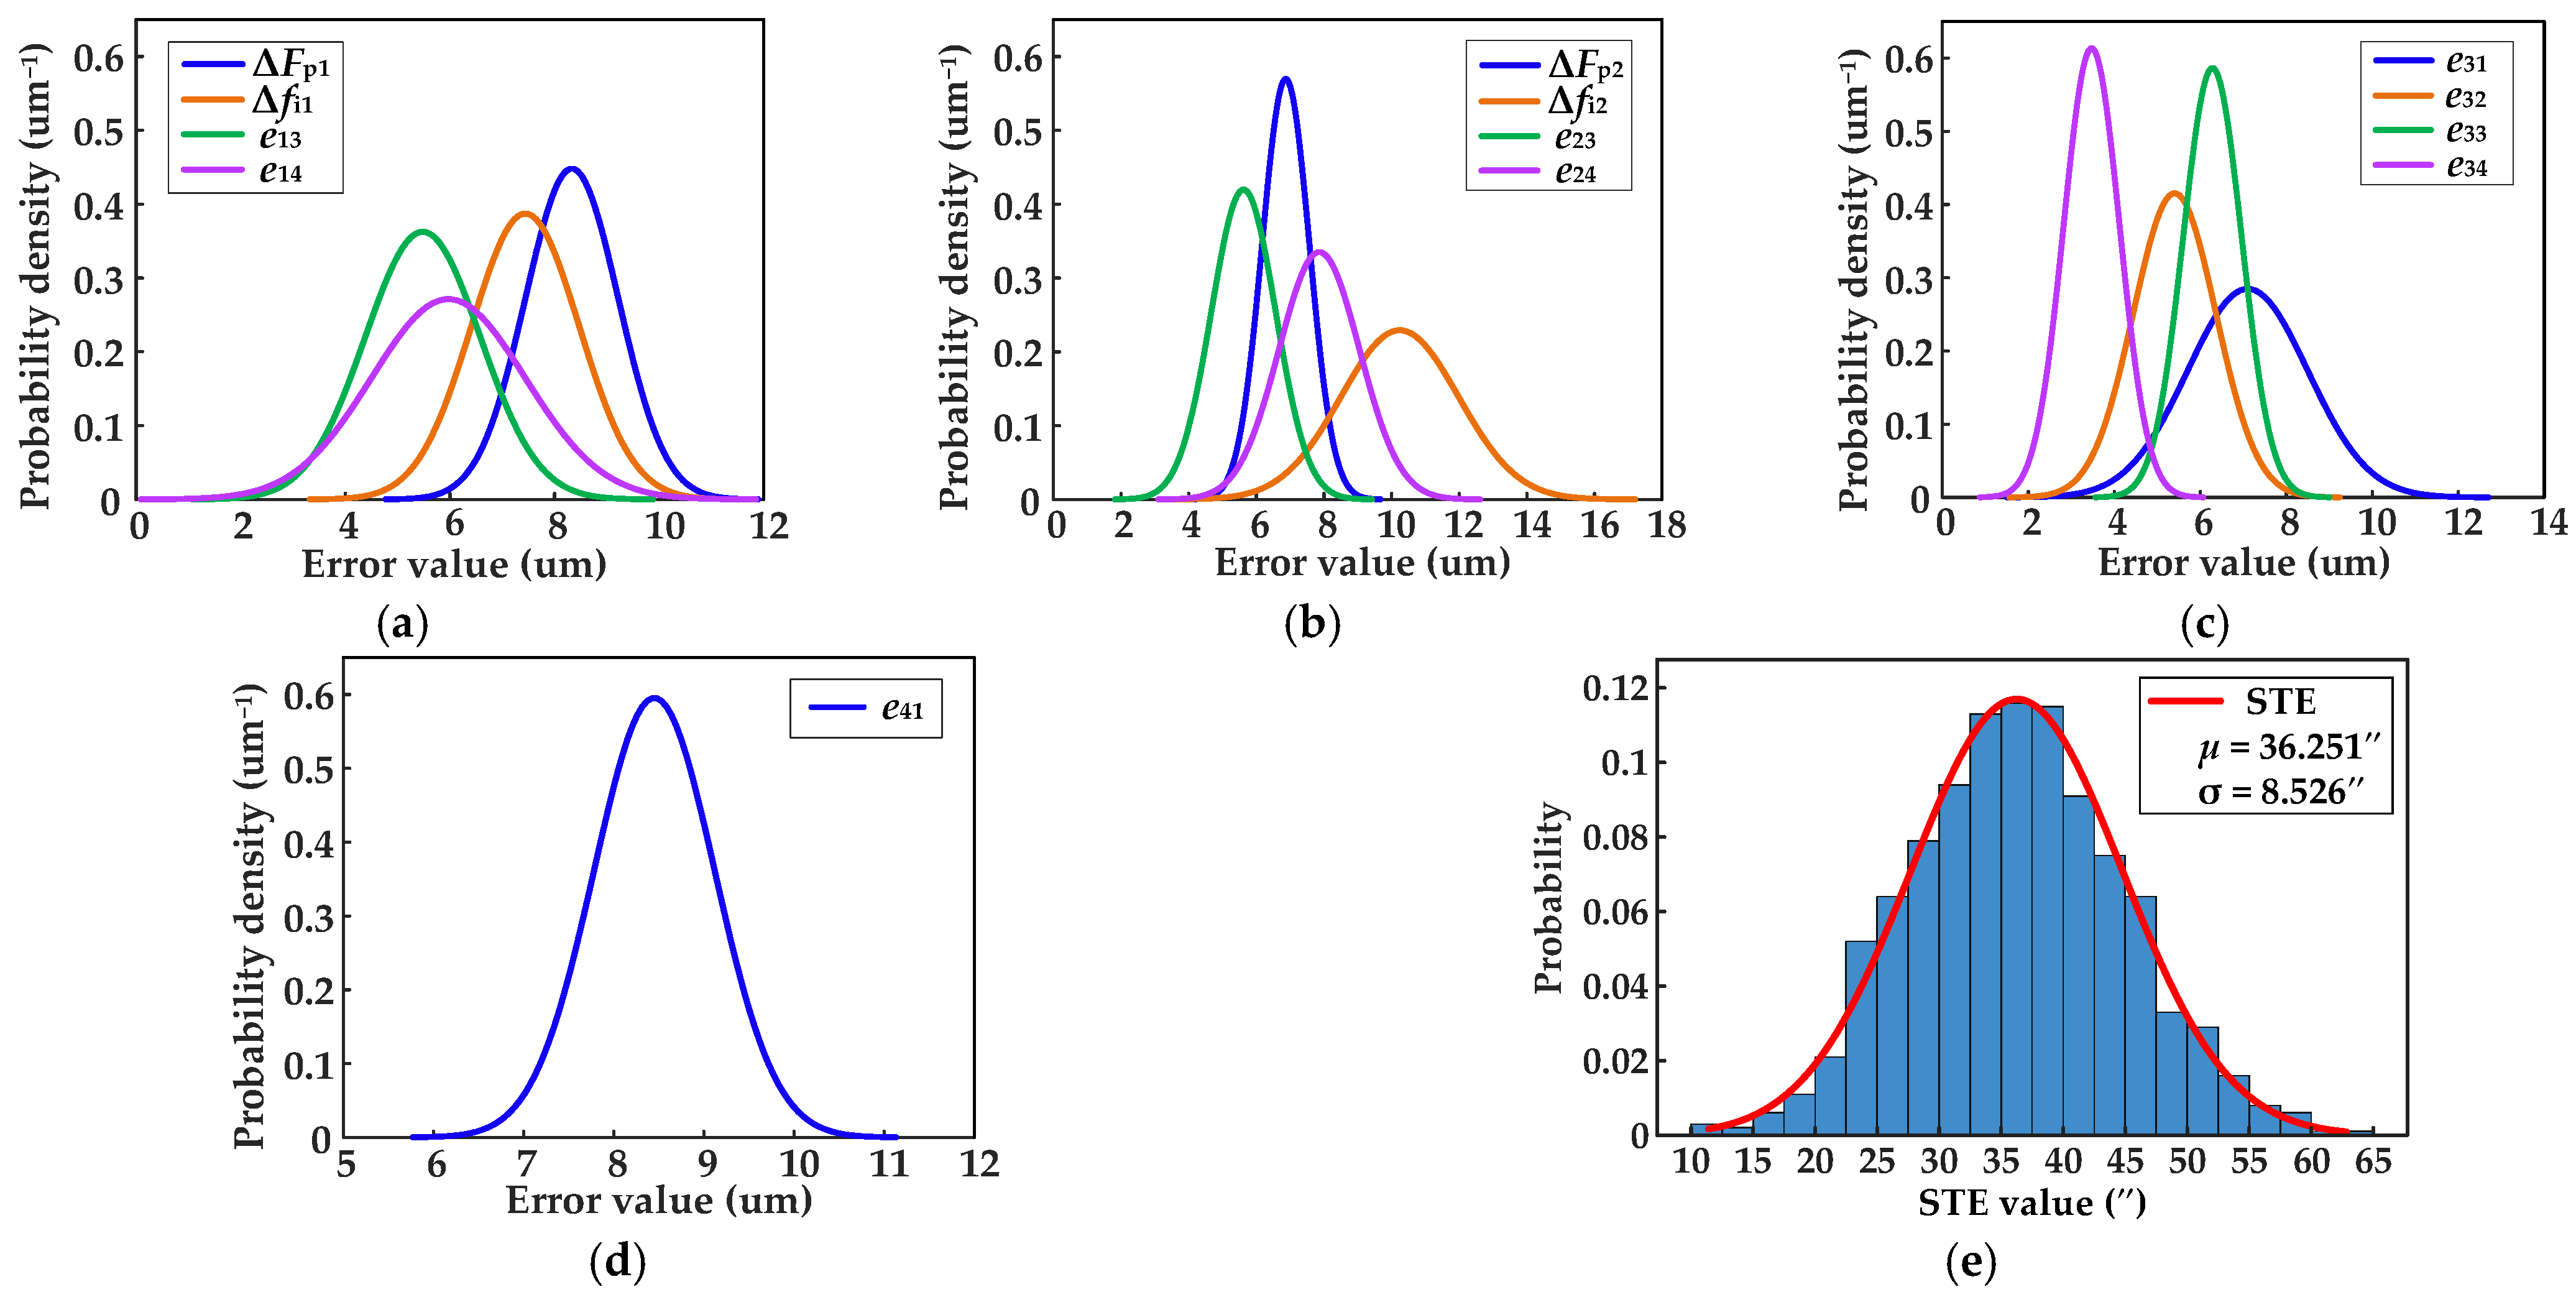
Based on the measured statistical parameters (
μ,
σ) of each error source, 1000 sets of mutually independent, normally distributed error samples were generated using the MC method combined with the 3
σ truncation criterion. Their probability distribution characteristics are shown in
Figure 5a–d. Meanwhile, the initial phase angles corresponding to each error in Equation (1) were assumed to be mutually independent and to follow a uniform distribution over the interval [0, 2π), and were also randomly sampled using the MC method. Subsequently, the generated error samples and phase angles were substituted into Equation (1) to calculate the total kinematic error, which was then substituted into Equation (2) for batch computation. Finally, the probability distribution and statistical characteristics of the STE for the harmonic drive were obtained, as shown in
Figure 5e.
2.2. System Dynamics Modeling and DTE Characterization
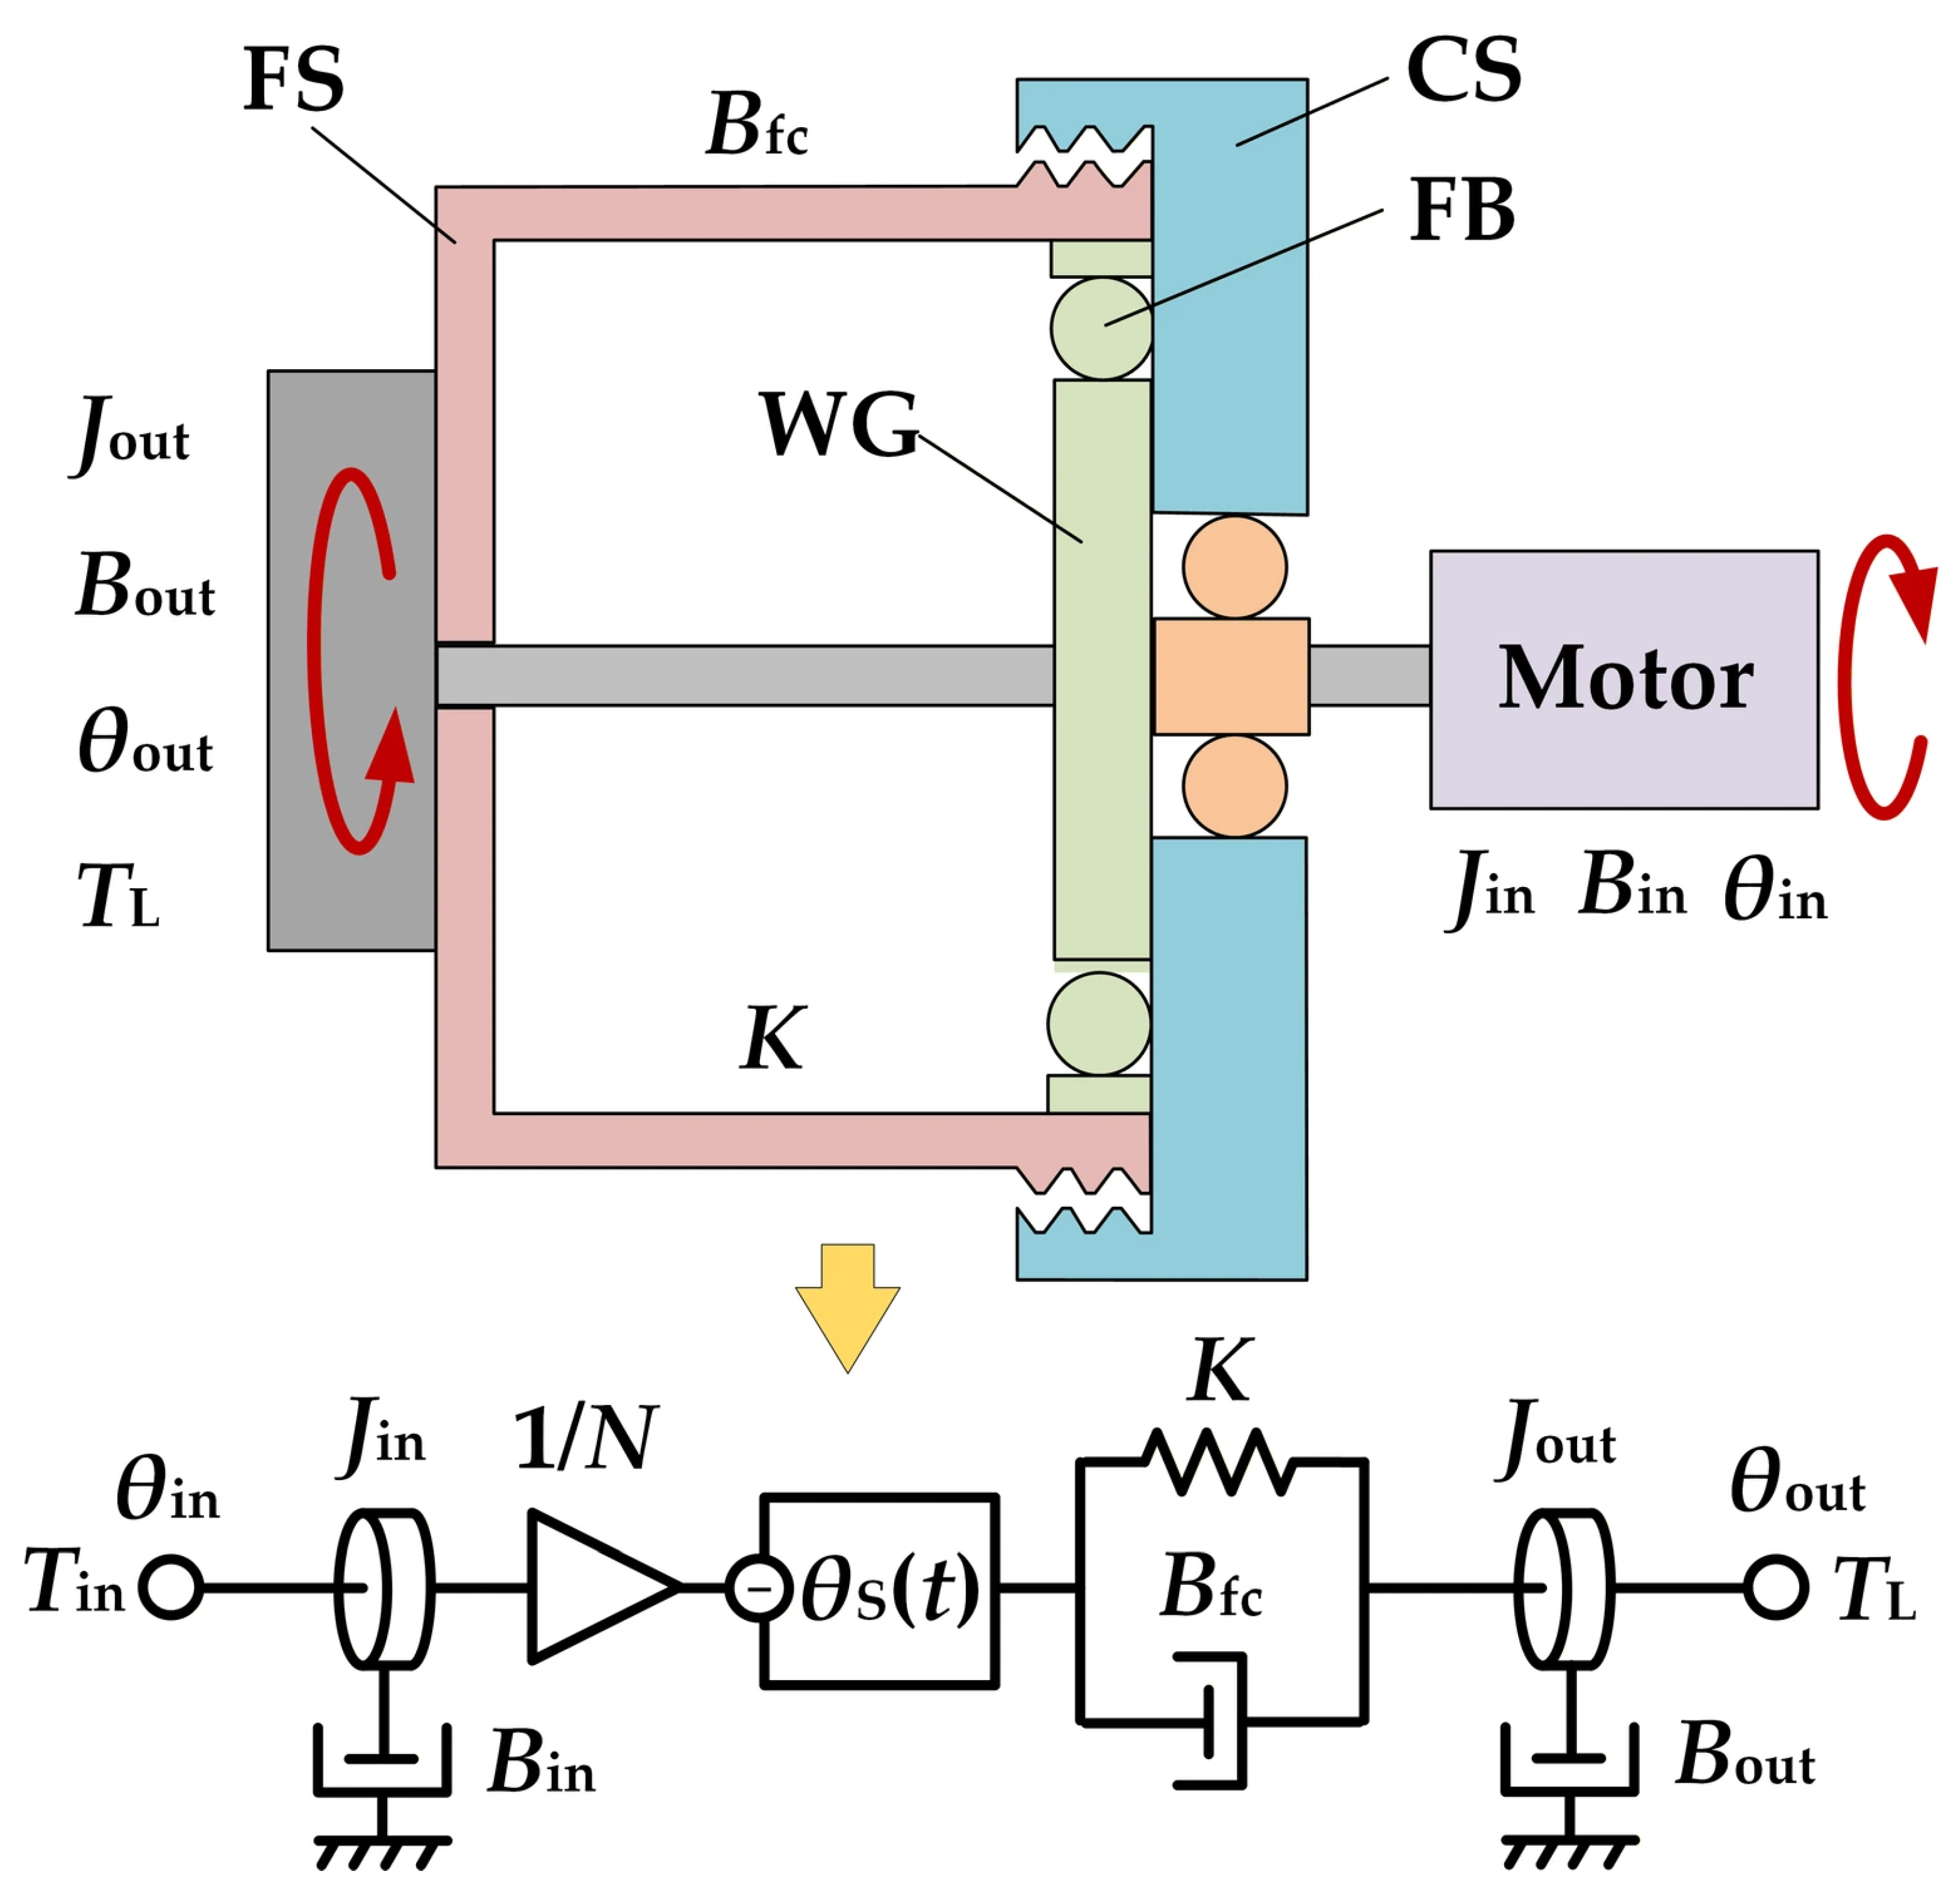
Based on the actual structure and working principle of the harmonic drive, its simplified physical model and the corresponding dynamic model are shown in
Figure 6.
The kinetic energy of the system is defined as
where
Jin and
Jout denote the equivalent moments of inertia of the input and output ends, respectively;
θin(
t) is the input angle of the WG; and
θout(
t) is the output angle of the FS.
The ideal output angle of the system is
θin(
t)/
N, where
N denotes the transmission ratio. The additional relative elastic deformation of the system is defined as
Correspondingly, the elastic potential energy of the system is given by
where
K represents the equivalent torsional stiffness.
The Lagrangian function of the system is defined as the difference between the kinetic energy and potential energy:
The equivalent viscous dissipation of the system is described by the Rayleigh dissipation function as
where
Bin is the equivalent viscous damping coefficient of the input end;
Bout is the equivalent viscous damping coefficient of the output end; and
Bfc is the lumped equivalent damping coefficient, representing the speed-dependent energy losses caused by flexible spline deformation, tooth meshing, lubrication, and related assembly factors.
The Lagrange dynamic equations of the system are expressed as
where
Tin(
t) is the driving torque applied by the motor to the input end, and
TL(
t) is the external load torque applied to the output end.
By substituting Equations (3)–(7) into Equation (8), the dynamic equations of the system are obtained as
The DTE of the harmonic drive is defined as the deviation between the ideal output angle and the actual output angle:
The preset excitations of the system comprise
Tin(
t),
θs(
t), and
TL(
t). A torque-driven mode is adopted in this study. To avoid transient impacts,
Tin(
t) is smoothly loaded from zero, enabling the system to maintain the rated rotational speed 2000 r/min (1 r/min corresponds to π/30 rad/s) during the steady-state stage. During the starting transition period,
TL(
t) is gradually loaded, and
θs(
t) is progressively introduced via a smooth envelope function. The system starts from a stationary, unloaded, and initial elastic deformation-free state, with the initial conditions defined as:
Under the torque-driven condition, Equation (9) is solved simultaneously, with θin(t), , θout(t), and serving as the system state variables. After the excitations reach a steady state, the system continues to operate for multiple complete cycles. By discarding the initial transient response, only the converged steady-state periodic data are utilized to calculate and analyze the DTE.
To verify the dimensional consistency of the established dynamic model, an inspection was conducted on Equations (3)–(11). First, concerning basic physical quantities, θin(t), θout(t), θs(t), and δA(t) are all expressed in rad; the units of Jin and Jout are kg·m2, the unit of K is N·m/rad, and the units of Bin, Bout, and Bfc are N·m·s/rad. On this basis, the various torques in the dynamic equations (such as , KδA(t)/N, and ) all possess the torque unit N·m, which is consistent with Tin(t) and TL(t). Furthermore, E and V defined in Equations (3) and (5) both have the energy unit J, while ψ defined in Equation (7) has the power unit W, which is consistent with their physical meanings. Therefore, the above dynamic equations strictly satisfy the dimensional consistency requirements.
2.3. Chebyshev Surrogate Modeling for DTE Under Probabilistically Characterized Uncertain Parameters
According to the Weierstrass approximation theorem, for any continuous function
f(
x)∈C[
a,
b] and a given approximation accuracy
ε > 0, there exists a polynomial
satisfying
where
ai∈ℝ. Within the polynomial set, there exists a unique best uniform approximation polynomial
pk*(
x)∈
Pk(
x), where the superscript “*” denotes the optimal approximation, satisfying
where
Ek(
f) is the lower bound of the maximum error, and
pk*(
x) is the
k-th order best uniform approximation polynomial of
f(
x). When
k > 2, directly solving for
pk*(
x) is difficult; thus, Chebyshev polynomials with excellent properties are commonly used to approximate
f(
x).
For the one-dimensional case, the
k-th order Chebyshev polynomial within the domain
x∈[−1, 1] is defined as
Ck(
x), with the algebraic expression:
where
θ = arccos(
x)∈[0, π]. If the actual physical variable lies within a general interval
x∈[
a,
b], a linear scale transformation
is applied, allowing it to be substituted into Equation (14).
The recurrence relationship and orthogonal characteristics of
Ck(
x) are as follows:
where
ρ(
x) is the Chebyshev space weight function, defined as
.
For a continuous function
f(
x)∈C[
a,
b], it can be expanded and approximated by a
k-th order Chebyshev polynomial:
where
fi represents the Chebyshev coefficients.
Under the weight function, integrating the product of
f(
x) and the Chebyshev series yields
According to Equation (16), the right side of Equation (18) is 0.5πfg, from which the expression for fi can be derived:
According to the interpolating integration formula,
, where
xq denotes the interpolation points, namely the roots of the
p-th order Chebyshev polynomial, with
and
(
q = 1,…,
p). Here,
p represents the highest order of the interpolating integration formula (
p =
k + 1). Then, Equation (19) can be transformed into
Extended to an
n-dimensional space, the definition of the
k-th order
n-dimensional Chebyshev series within the standard hypercube
x = (
x1,…,
xn)∈[–1, 1]
n is given in the tensor product form of the series of each dimension:
where
k = (
k1,…,
kn), and
θi = arccos(
xi)∈[0, π].
For a high-dimensional target response function
f(
x), its approximate expansion using a
k-th order
n-dimensional Chebyshev polynomial series can be expressed as
where
i = (
i1,…,
ij,…,
in) is the multidimensional summation index vector;
h is the number of zero elements in
i; and
fi is the
n-th order Chebyshev coefficient tensor, which can be computed via the multidimensional numerical integration formula:
The interpolation points in Equation (23) constitute an
n-dimensional tensor product lattice, which is the tensor product form of all one-dimensional interpolation point sets
Xi:
Define the uncertain parameter vector of the harmonic drive as
ξ = [
ξ1,…,
ξn]
T (physically corresponding to
θs,
K,
Jin,
Bin, and
Bfc). Express the variation range of the uncertain parameters in interval form as [
ξ] = ([
ξ1],…,[
ξn])
T = [
ξl,
ξu]. This actual physical interval can be mapped to the standard interval vector [
δ] = [–1, 1]
n via a linear transformation:
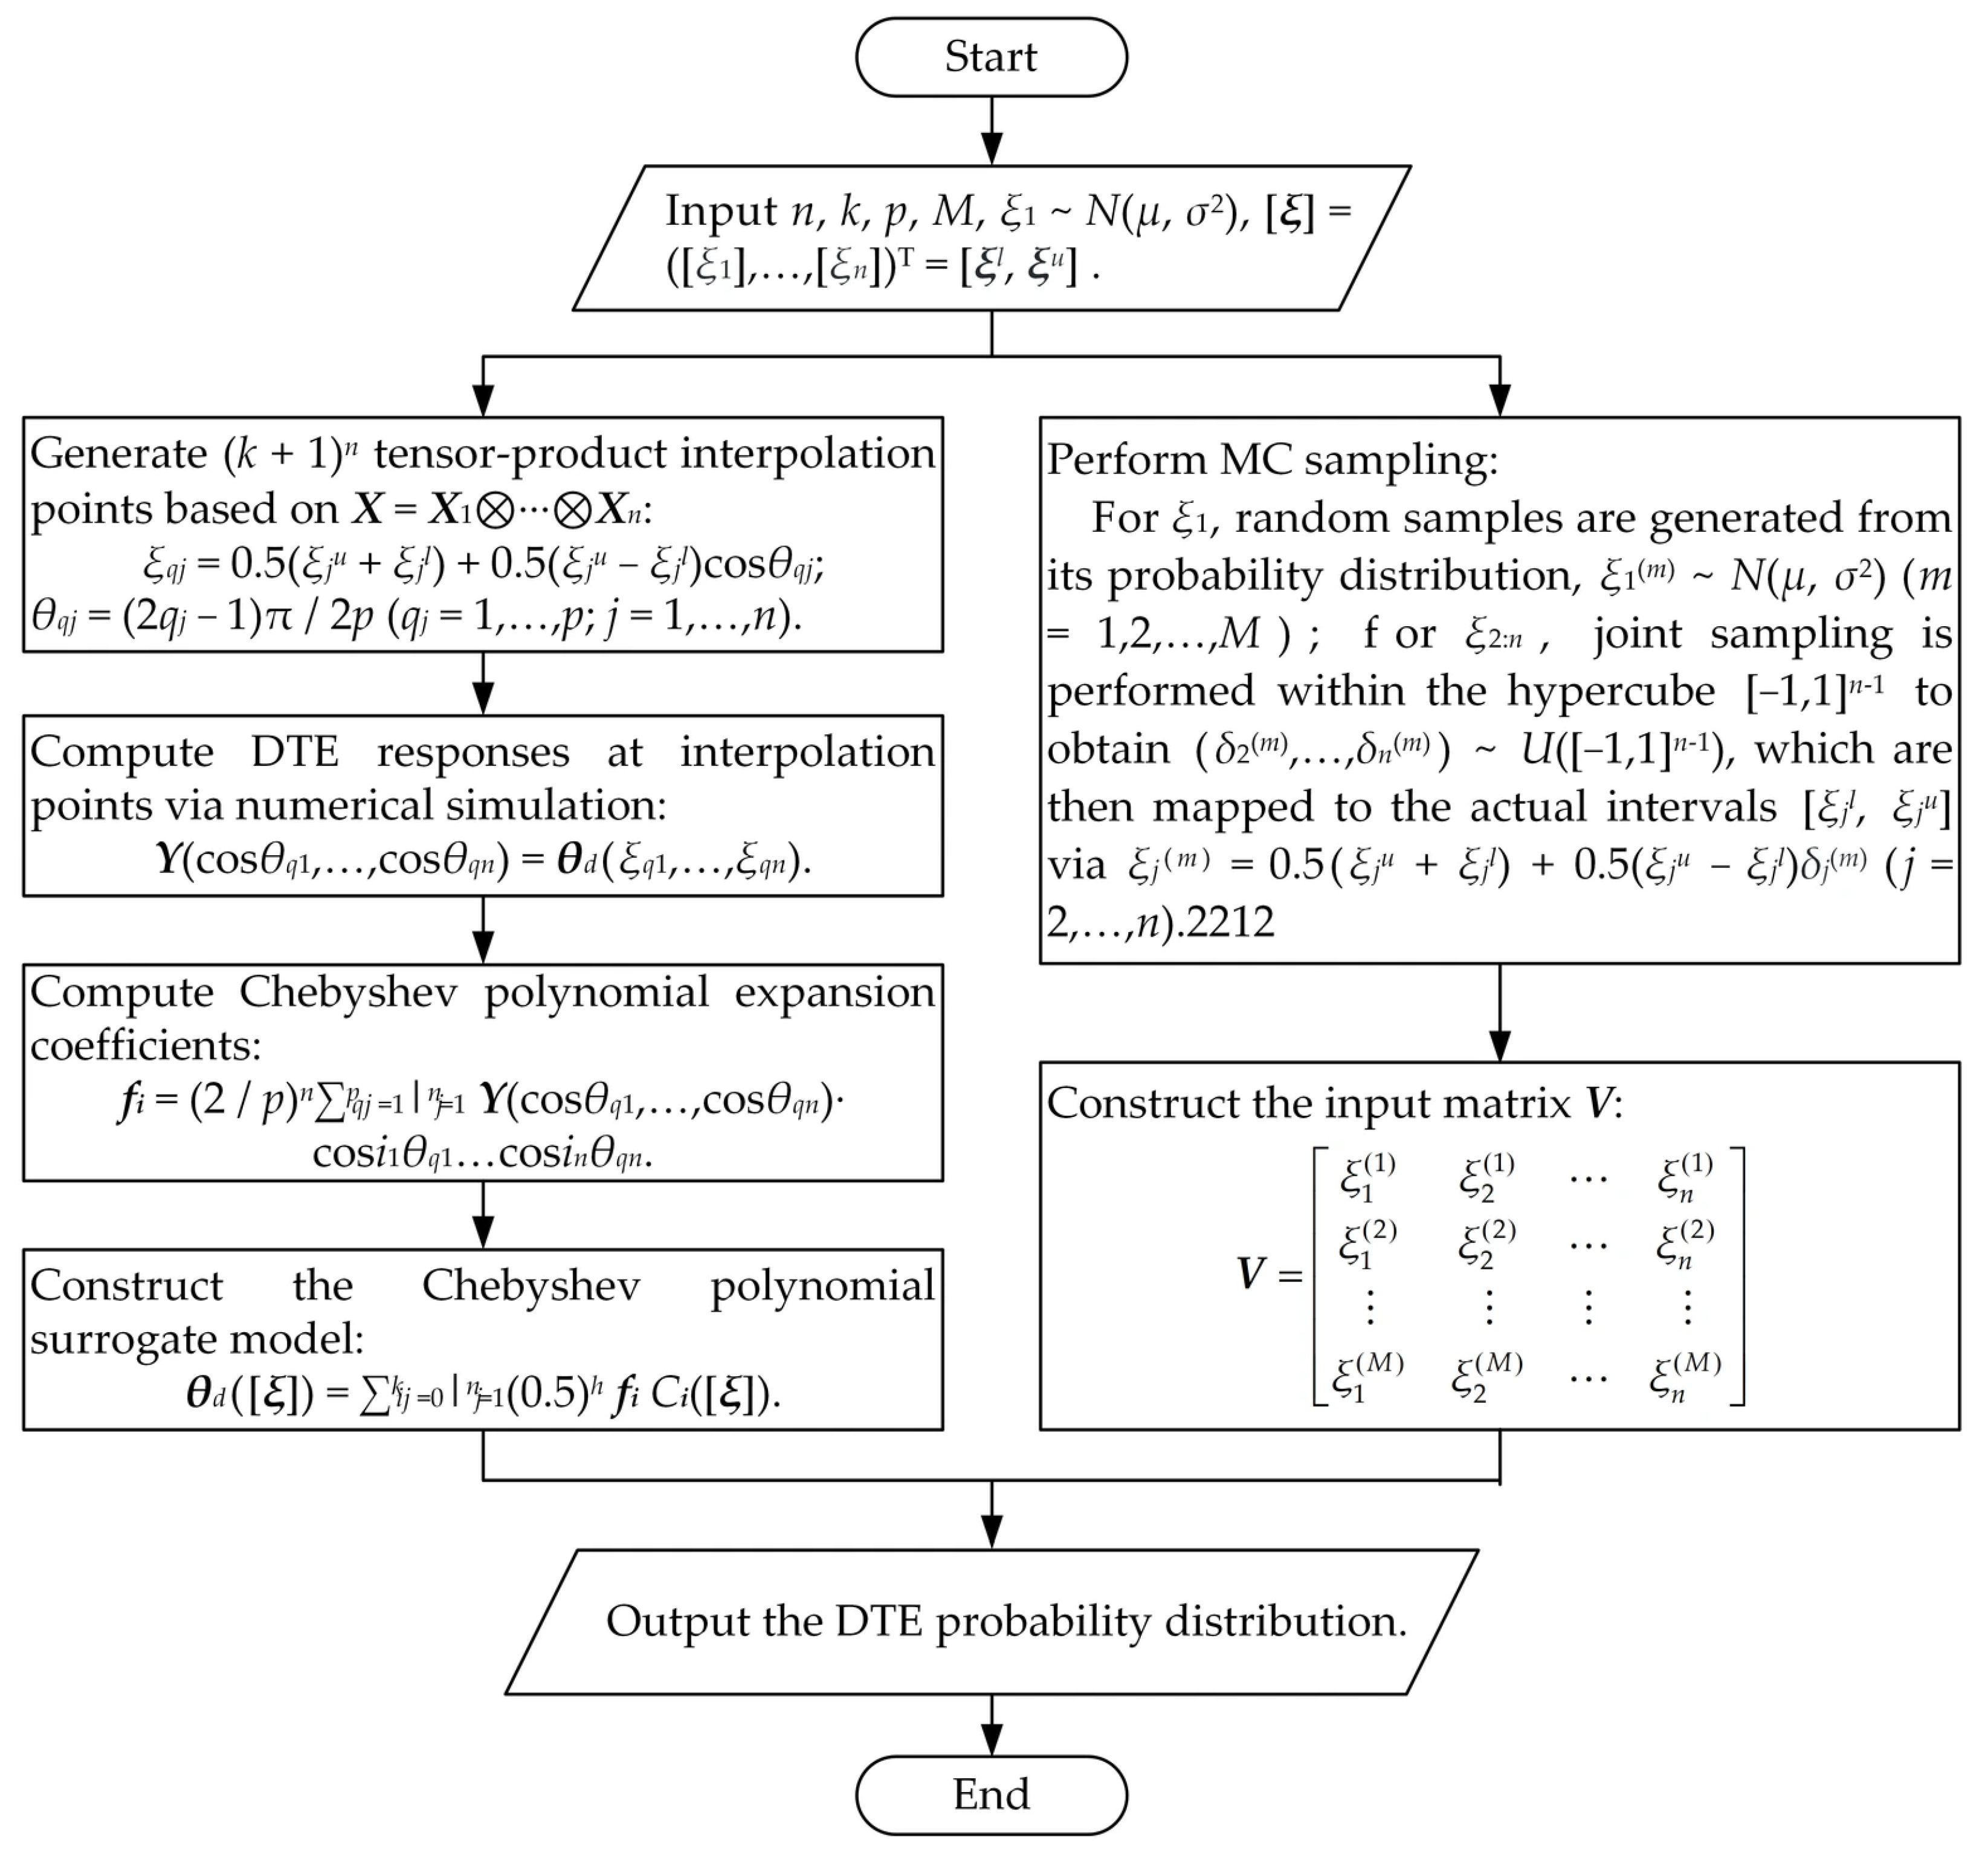
The Chebyshev surrogate modeling process for DTE under probabilistically characterized uncertain parameters is as follows: first, (
k + 1)
n tensor-product interpolation sampling points are determined according to Equation (24), where the calculation formula for each interpolation point is given by
, with
(
qj = 1,…,
p;
j = 1,…,
n). The total number of sampling points satisfies the lower bound constraint of (
k +
n)!/(
k!
n!). By numerically solving the original dynamic model, the output response at each specific sampling point is obtained as
Y(cos
θq1,…,cos
θqn) =
θd(
ξq1,…,
ξqn), and the expansion coefficients of the Chebyshev polynomial are constructed as
, thereby establishing the Chebyshev polynomial surrogate model of DTE as
. Subsequently, MC random sampling is performed. For the uncertain parameter
ξ1, samples are generated from the probability distribution in
Figure 5e as
ξ1(m) ~
N(
μ,
σ2) (
m = 1,2,…,
M), while for the uncertain parameters
ξ2:n, joint sampling is conducted within the standard hypercube space [–1, 1]
n−1 as (
δ2(m),…,
δn(m)) ~
U([–1, 1]
n−1), which are then mapped to the actual physical intervals [
ξjl,
ξju] via the linear transformation
(
j = 2,…,
n). The input matrix is constructed as
, and by substituting
V into the Chebyshev polynomial surrogate model, the probability distribution of DTE can be rapidly calculated. The aforementioned modeling workflow is illustrated in
Figure 7.
3. Dynamic Parameter Identification and DTE Case Study
To establish a high-precision DTE model, the nominal values of the core dynamic parameters must be determined. This section adopts a combined approach of theoretical calculation and experimental identification to obtain the relevant parameters. These values serve as the direct input for the baseline DTE case study and provide deterministic baseline center data for the subsequent multi-objective robust optimization.
Among the dynamic parameters, the nominal values of
Jin and
Jout are directly extracted from the theoretical geometric models of the corresponding components (the WG assembly and the CS assembly) via SOLIDWORKS 2023. Conversely, the nominal values of
K,
Bin,
Bfc, and
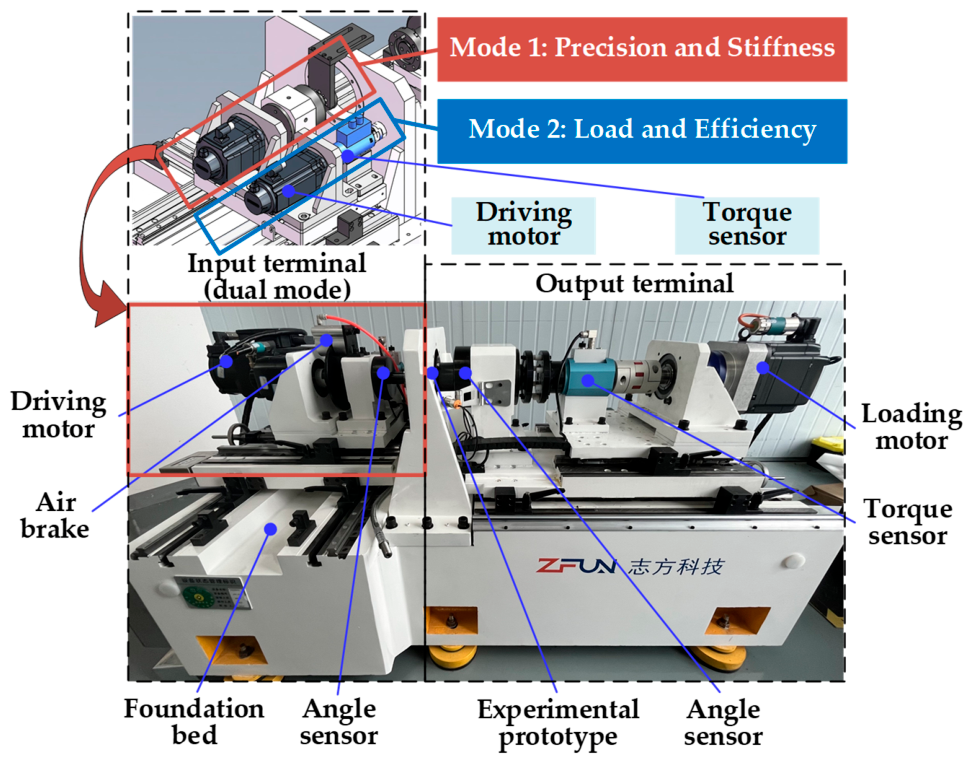
Bout are determined by performing independent decoupled tests on 20 experimental prototypes of the same model using a comprehensive performance test platform for harmonic drives, and taking the arithmetic mean of the experimental values of each prototype after obtaining them. The overall structural layout of the test platform is shown in
Figure 8, which integrates a high-precision driving motor, a loading motor, and torque and angle sensors, thereby achieving independent decoupled testing of different dynamic parameters through flexibly switching testing modes with different sensor combinations.
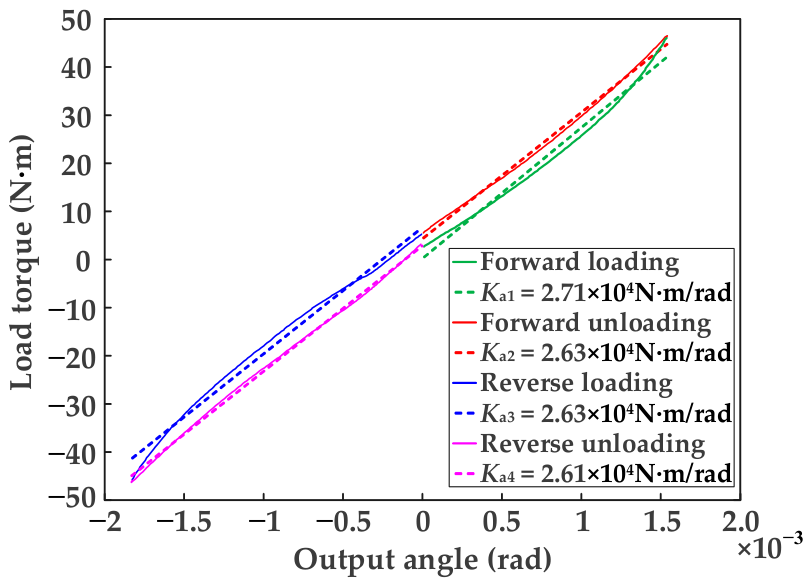
By using Mode 1 of the comprehensive performance test platform, the harmonic drive prototype is installed on the test platform, and its input terminal is rotationally locked using a pneumatic brake. Subsequently, the output loading motor is controlled to gradually increase the torque from zero to a positive nominal torque of 40 N·m, before being smoothly unloaded back to zero; it is then progressively loaded in the reverse direction to a nominal torque of −40 N·m and symmetrically unloaded to zero. During this process, the output torque and angular responses are recorded in real time by the high-precision torque and angle sensors located at the output terminal, thereby plotting the torque-torsion angle hysteresis curve as shown in
Figure 9.
The DTE model adopted in this study mainly characterizes a monotonically increasing positive load from 0 to 40 N·m, excluding the unloading and torque reversal stages. Therefore, instead of averaging the slopes of four mechanically distinct branches (namely, the slope
Ka1 of the forward loading curve segment
a1, the slope
Ka2 of the forward unloading curve segment
a2, the slope
Ka3 of the reverse loading curve segment
a3, and the slope
Ka4 of the reverse unloading curve segment
a4), the stiffness parameter
K is identified specifically based on the forward loading branch. Following the branch-specific treatment of Ma et al. [
39], the slope
Ka1 obtained by least-squares linear fitting of the forward loading data is adopted as the equivalent torsional stiffness
K of the prototype, i.e.,
K =
Ka1.
The test platform is switched to Mode 2 to sequentially identify the experimental values of each damping coefficient through a layer-by-layer installation and progressive decoupling of transmission components.
First, the experimental identification of parameter
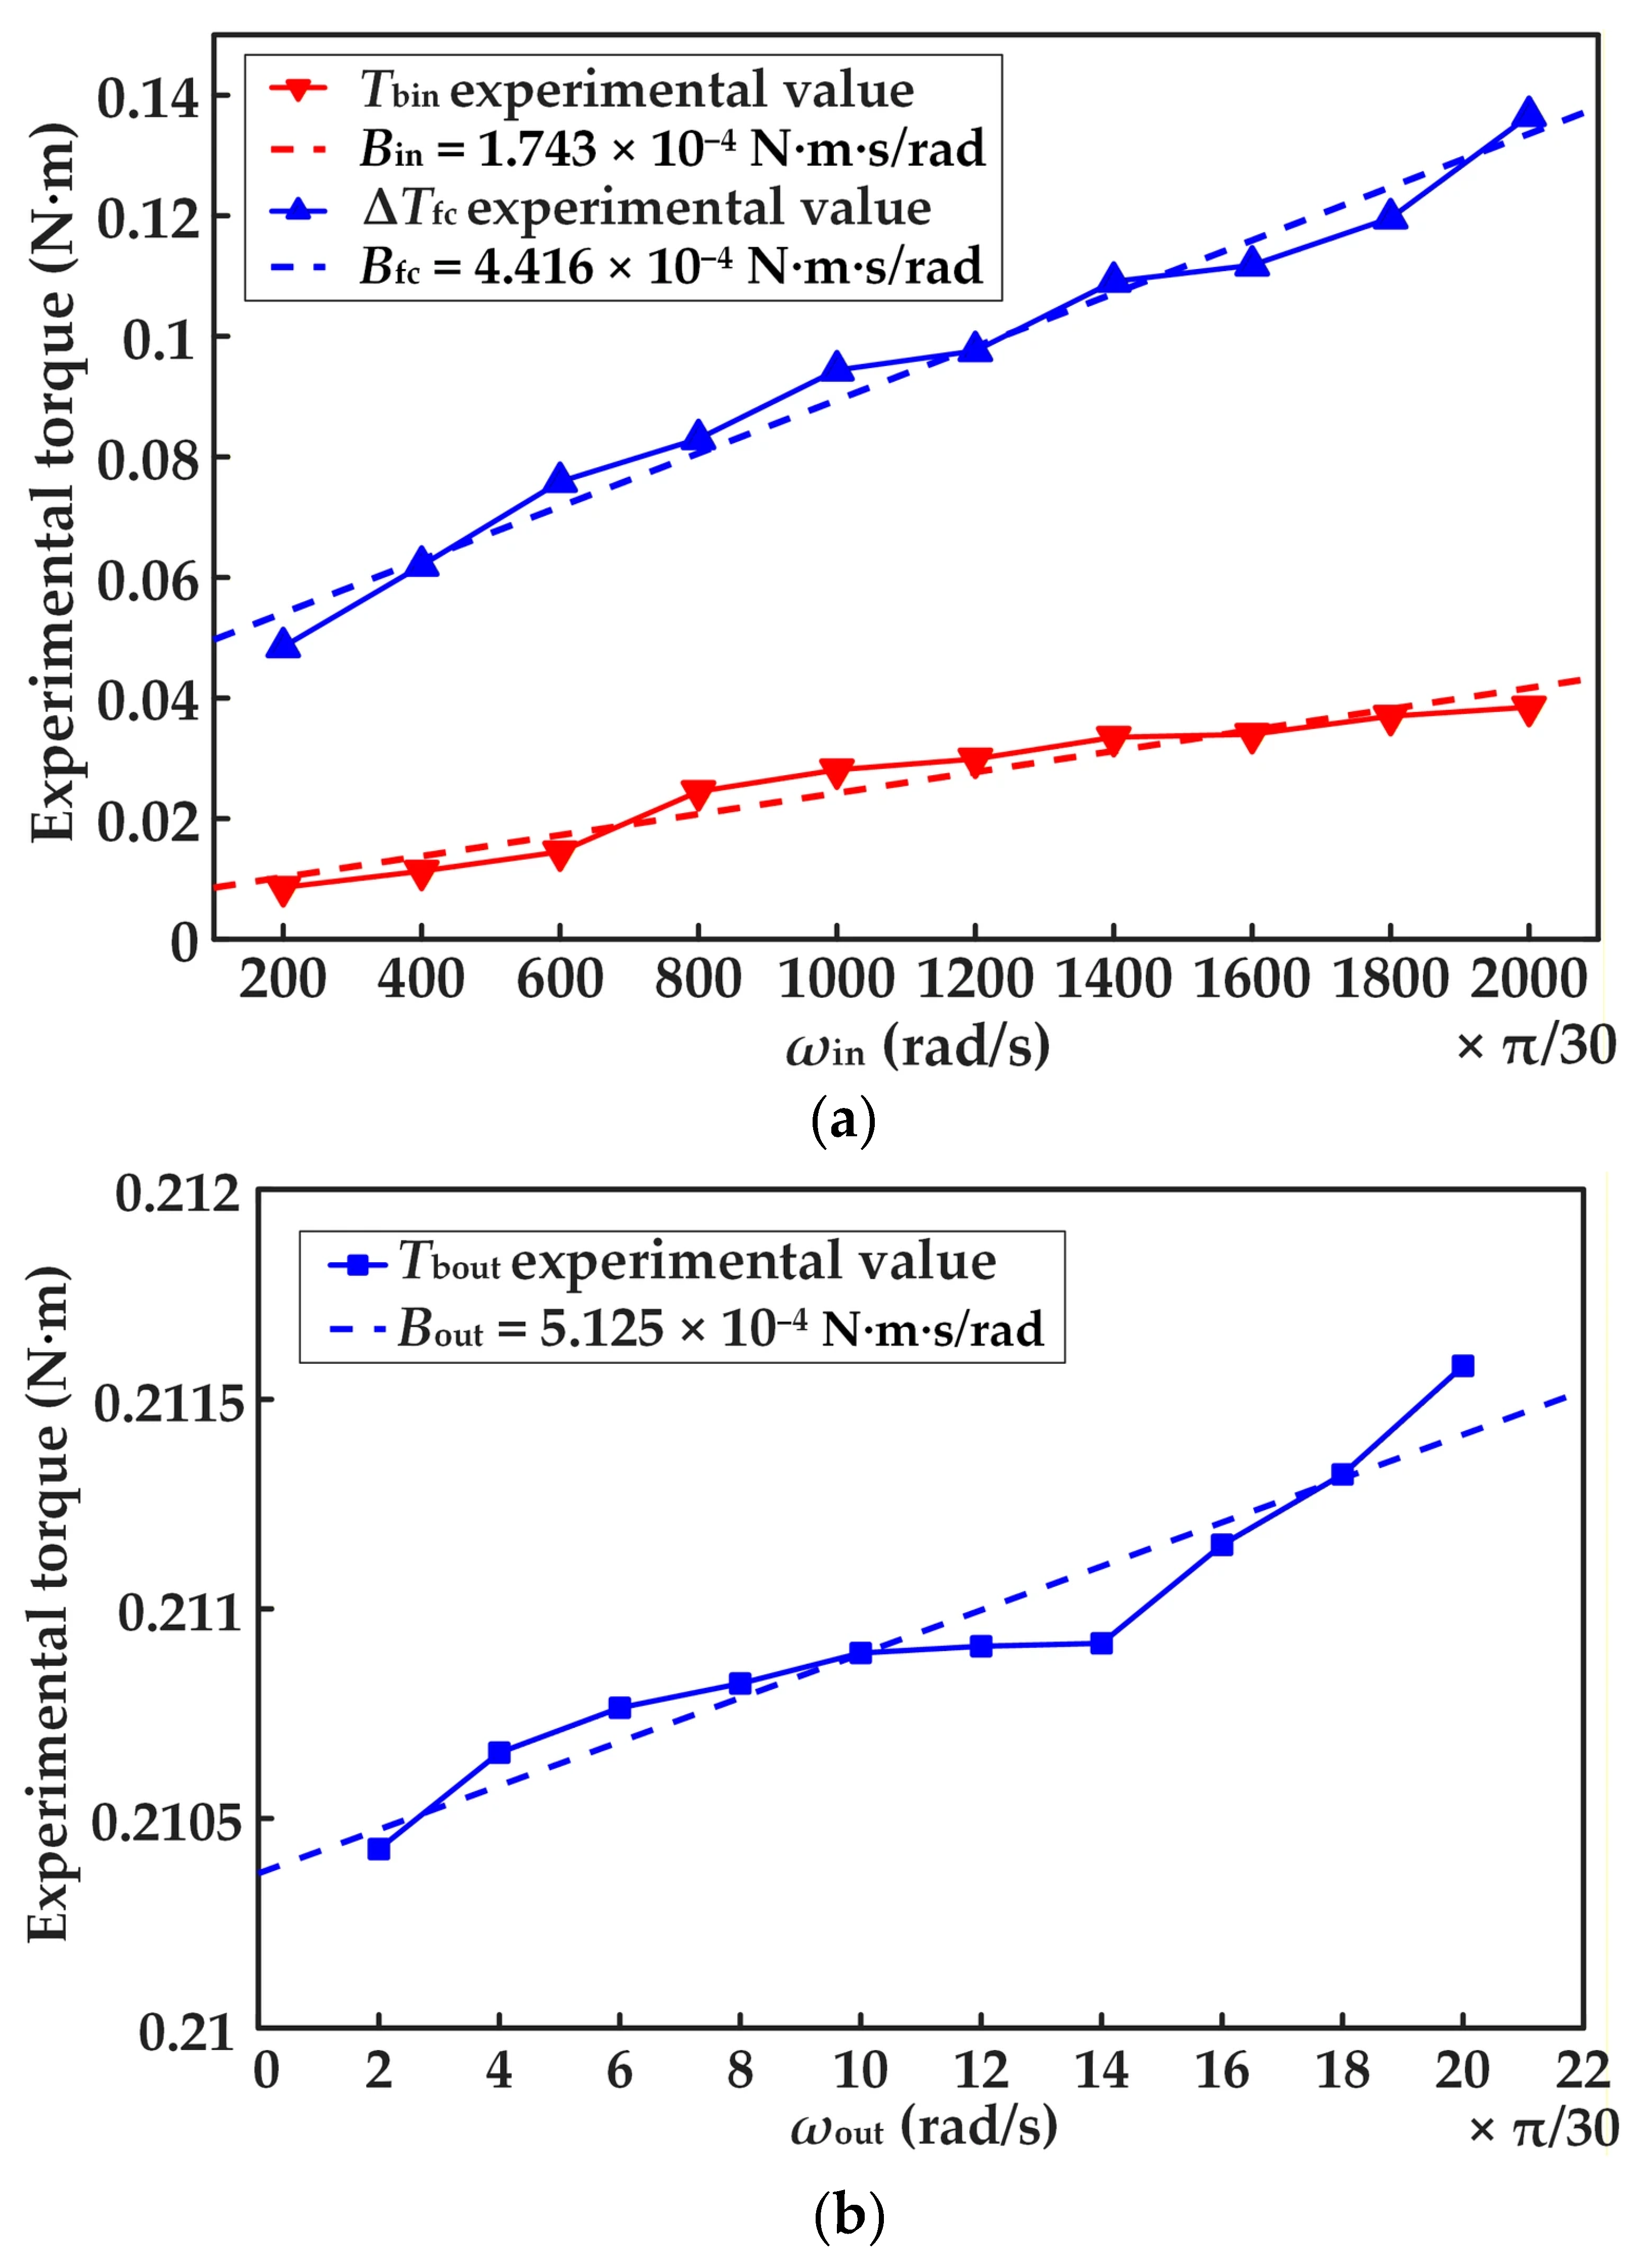
Bin is performed. In the experiment, the test prototype only retains the WG and the FB, and the outer ring of the FB is rigidly fixed. The input drive motor is controlled to gradually increase the input speed
ωin from 200 r/min to 2000 r/min, and the test step is set to 200 r/min. The variation data of the no-load torque
Tbin(
ωin) measured by the input torque sensor are recorded, and its fitting mathematical model is shown as Equation (26). The least squares method is used to perform linear fitting on the experimental data, and the slope of the straight line is the experimental value of
Bin.
Upon completing the identification of
Bin, while keeping the drive motor, torque sensor, sampling settings, and speed stepping conditions unchanged, the FS and CS are further installed to construct a complete assembly state comprising WG, FB, FS, and CS. Once each rotational speed stabilizes, the input no-load torque
Tbfc(
ωin) is recorded. Compared with the baseline assembly state, the complete assembly state introduces additional speed-dependent losses, such as FS cyclic deformation, FS-CS meshing, and their associated lubrication. Based on the lumped-parameter modeling approach, these additional speed-dependent dissipations are uniformly characterized in this study as the lumped equivalent damping coefficient
Bfc for the FS deformation and meshing processes.
To eliminate the influence of inherent losses at the input terminal, the torque difference ΔTfc between the complete assembly state and the baseline assembly state at identical rotational speeds is calculated, and least-squares linear fitting is performed according to Equation (27). Here, the fitted slope is defined as the lumped equivalent damping coefficient Bfc.
Finally, the experimental identification of
Bout is conducted. The load-bearing bearing assembly at the output terminal is tested separately. In this test, only the cross-roller bearing and the CS are retained, and the inner ring of the cross-roller bearing is rigidly fixed. The output motor is controlled to drive the CS to rotate, gradually increasing the output speed
ωout from 2 r/min to 20 r/min with a test step of 2 r/min. The variation in the no-load torque
Tbout(
ωout) measured by the output torque sensor is recorded. Equation (28) is utilized to perform linear fitting, and the slope of the fitted straight line is the experimental value of
Bout.
In Equations (26)–(28), abin, afc, and about are the vertical intercepts of the respective linear fitting curves. They serve to absorb effects that are approximately independent of the rotational speed within the test range, such as Coulomb friction, assembly preload, sealing/lubrication resistance, and sensor bias. Consequently, Bin, Bfc, and Bout should be regarded as lumped equivalent speed-dependent damping coefficients under specified assembly, lubrication, and temperature conditions, rather than the pure viscous damping of a single material.
Taking one harmonic drive prototype as an example, the fitting curves of each damping coefficient and the corresponding identification results obtained are shown in
Figure 10.
Bin,
Bfc, and
Bout are independently identified three times on each of the 20 prototypes. The average of the three tests for each prototype is taken as its identified parameter value. Based on the identification results of the 20 prototypes, the overall mean (
μp), inter-prototype standard deviation (
Sp), and coefficient of variation (CV) are calculated for each parameter, with the results summarized in
Table 3.
As shown in
Table 3, the CV for
Bin,
Bfc, and
Bout are 9.08%, 4.68%, and 5.57%, respectively, indicating that the dispersion of the identified parameters among different prototypes is generally limited. Therefore, under assembly, lubrication, temperature, and forward rotation conditions consistent with the identification experiments, it is statistically reasonable to adopt the mean values
μp of each equivalent damping coefficient from the 20 prototypes as their corresponding nominal values.
The finally determined nominal values for each parameter of the HS-20-100 harmonic drive are presented in
Table 4.
The transmission ratio of this model of harmonic drive is 101. Under rated working conditions, the input speed is 2000 r/min, and the load torque is 40 N·m. Considering that the large transmission ratio results in an extremely low operating speed at the output terminal (only 19.8 r/min), and that the influence of the FS free deformation damping is much smaller than that of the tooth surface meshing damping when the entire assembly is loaded, Jout and Bout are treated as deterministic parameters and directly take their nominal values. Meanwhile, θs, K, Jin, Bin and Bfc are treated as uncertain parameters.
The fluctuation range of each uncertain dynamic parameter is set to ±35% of its nominal value. To determine the optimal polynomial order
k of the 5D Chebyshev surrogate model and evaluate the model’s generalization ability across the prescribed parameter space, Latin hypercube sampling (LHS) is employed to generate 500 independent test points within this space. These 500 test points are solely used to evaluate the model accuracy and are not involved in the construction process of the candidate surrogate models of any order (
k = 2, 3, 4).
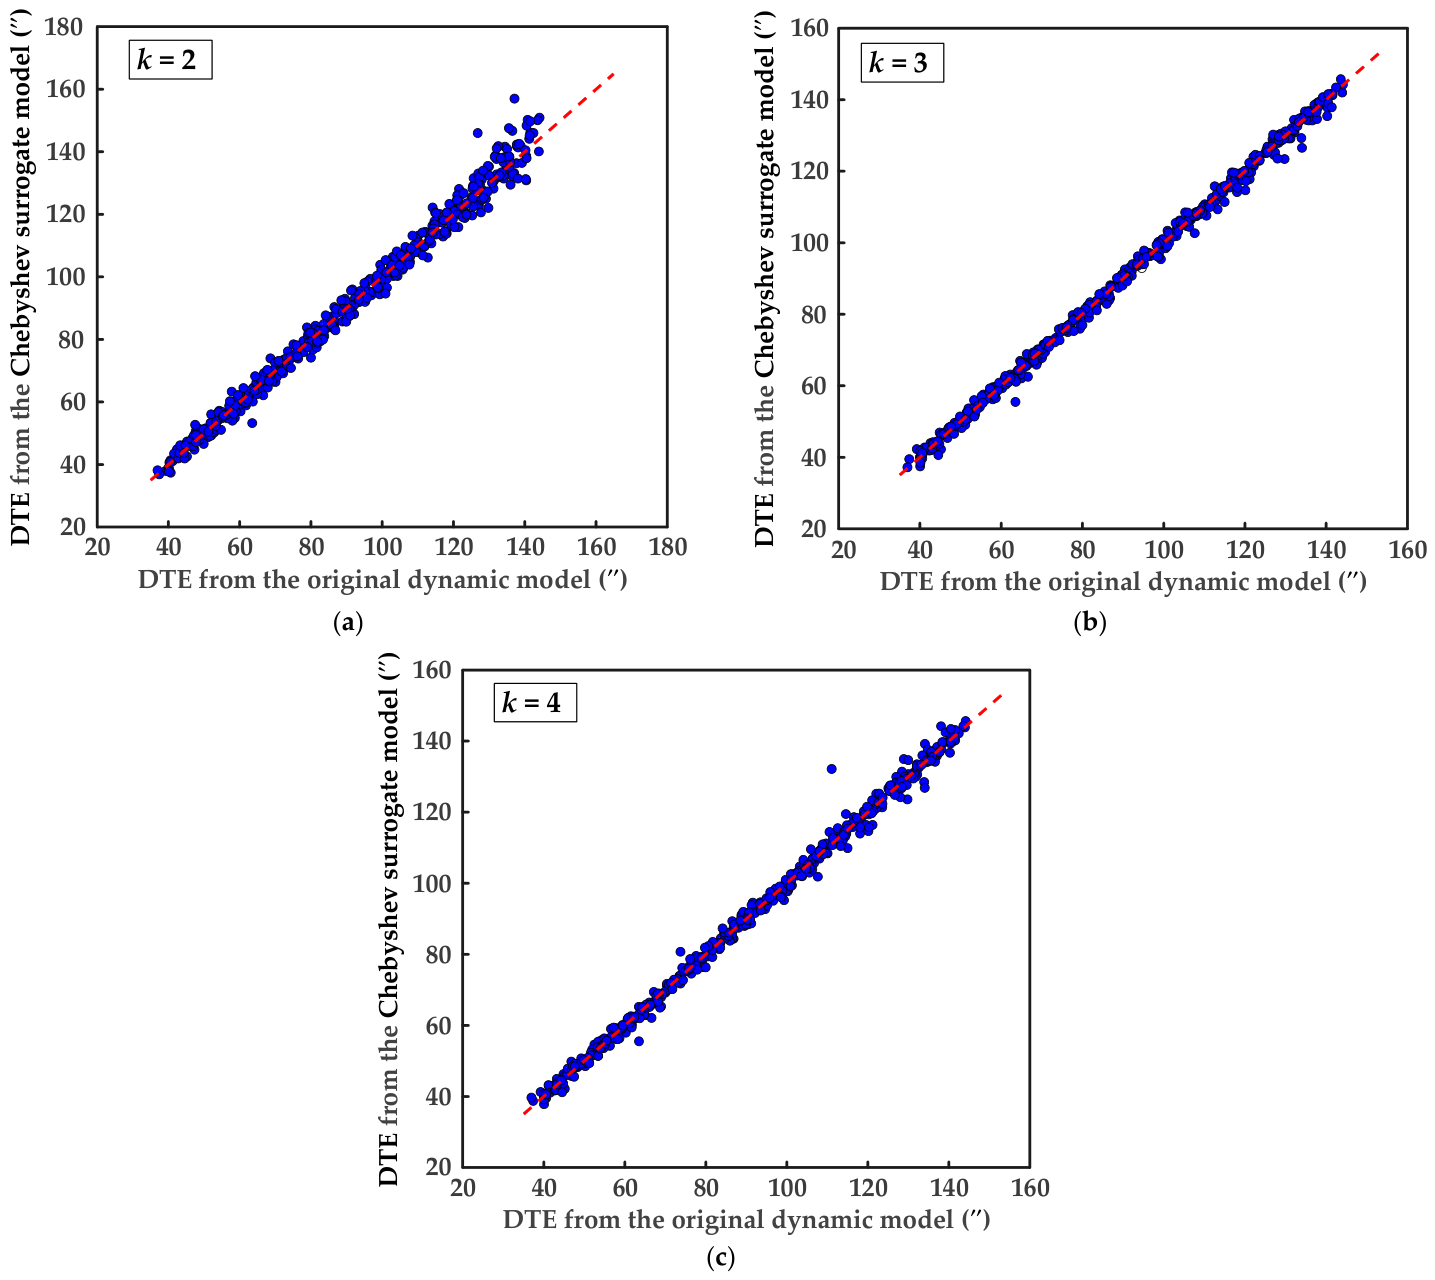
Figure 11 compares the predicted DTE values of the surrogate model and the original dynamic model at the independent test points under different orders
k. Simultaneously, five quantitative indicators are adopted for precise evaluation: mean absolute error (MAE), root mean square error (RMSE), mean absolute percentage error (MAPE), maximum absolute error (Max Error), and coefficient of determination (
R2). The results are presented in
Table 5.
As shown in
Table 5, when the order increases from
k = 2 to
k = 3, the model’s prediction accuracy improves significantly (with
R2 reaching the optimal value of 0.998). However, when the order further increases to
k = 4, the error indicators rise instead of falling (e.g., RMSE increases to 1.925″ and Max Error increases to 21.109″), indicating that an excessively high order induces local overfitting. Comprehensively considering both prediction accuracy and computational cost, this paper ultimately determines the optimal polynomial order as
k = 3.
Under a unified hardware environment (Intel Core i5-11300H CPU, 16 GB RAM), the computational costs and advantages of the surrogate model were systematically quantified. The surrogate model construction phase required a total of 1024 evaluations of the original model. For a single evaluation, the original model took 0.147 s while the surrogate model required only 0.000003 s. This time reduction achieves an acceleration ratio of 49,000. Furthermore, in a Monte Carlo (MC) analysis involving 1000 evaluations, the actual sequential execution time for the original model was 128.83 s. The surrogate model completed the same task in only 0.0030 s, reaching a batch-evaluation acceleration ratio of 42,943. These data intuitively demonstrate the extremely high computational efficiency of the surrogate model in large-sample evaluations.
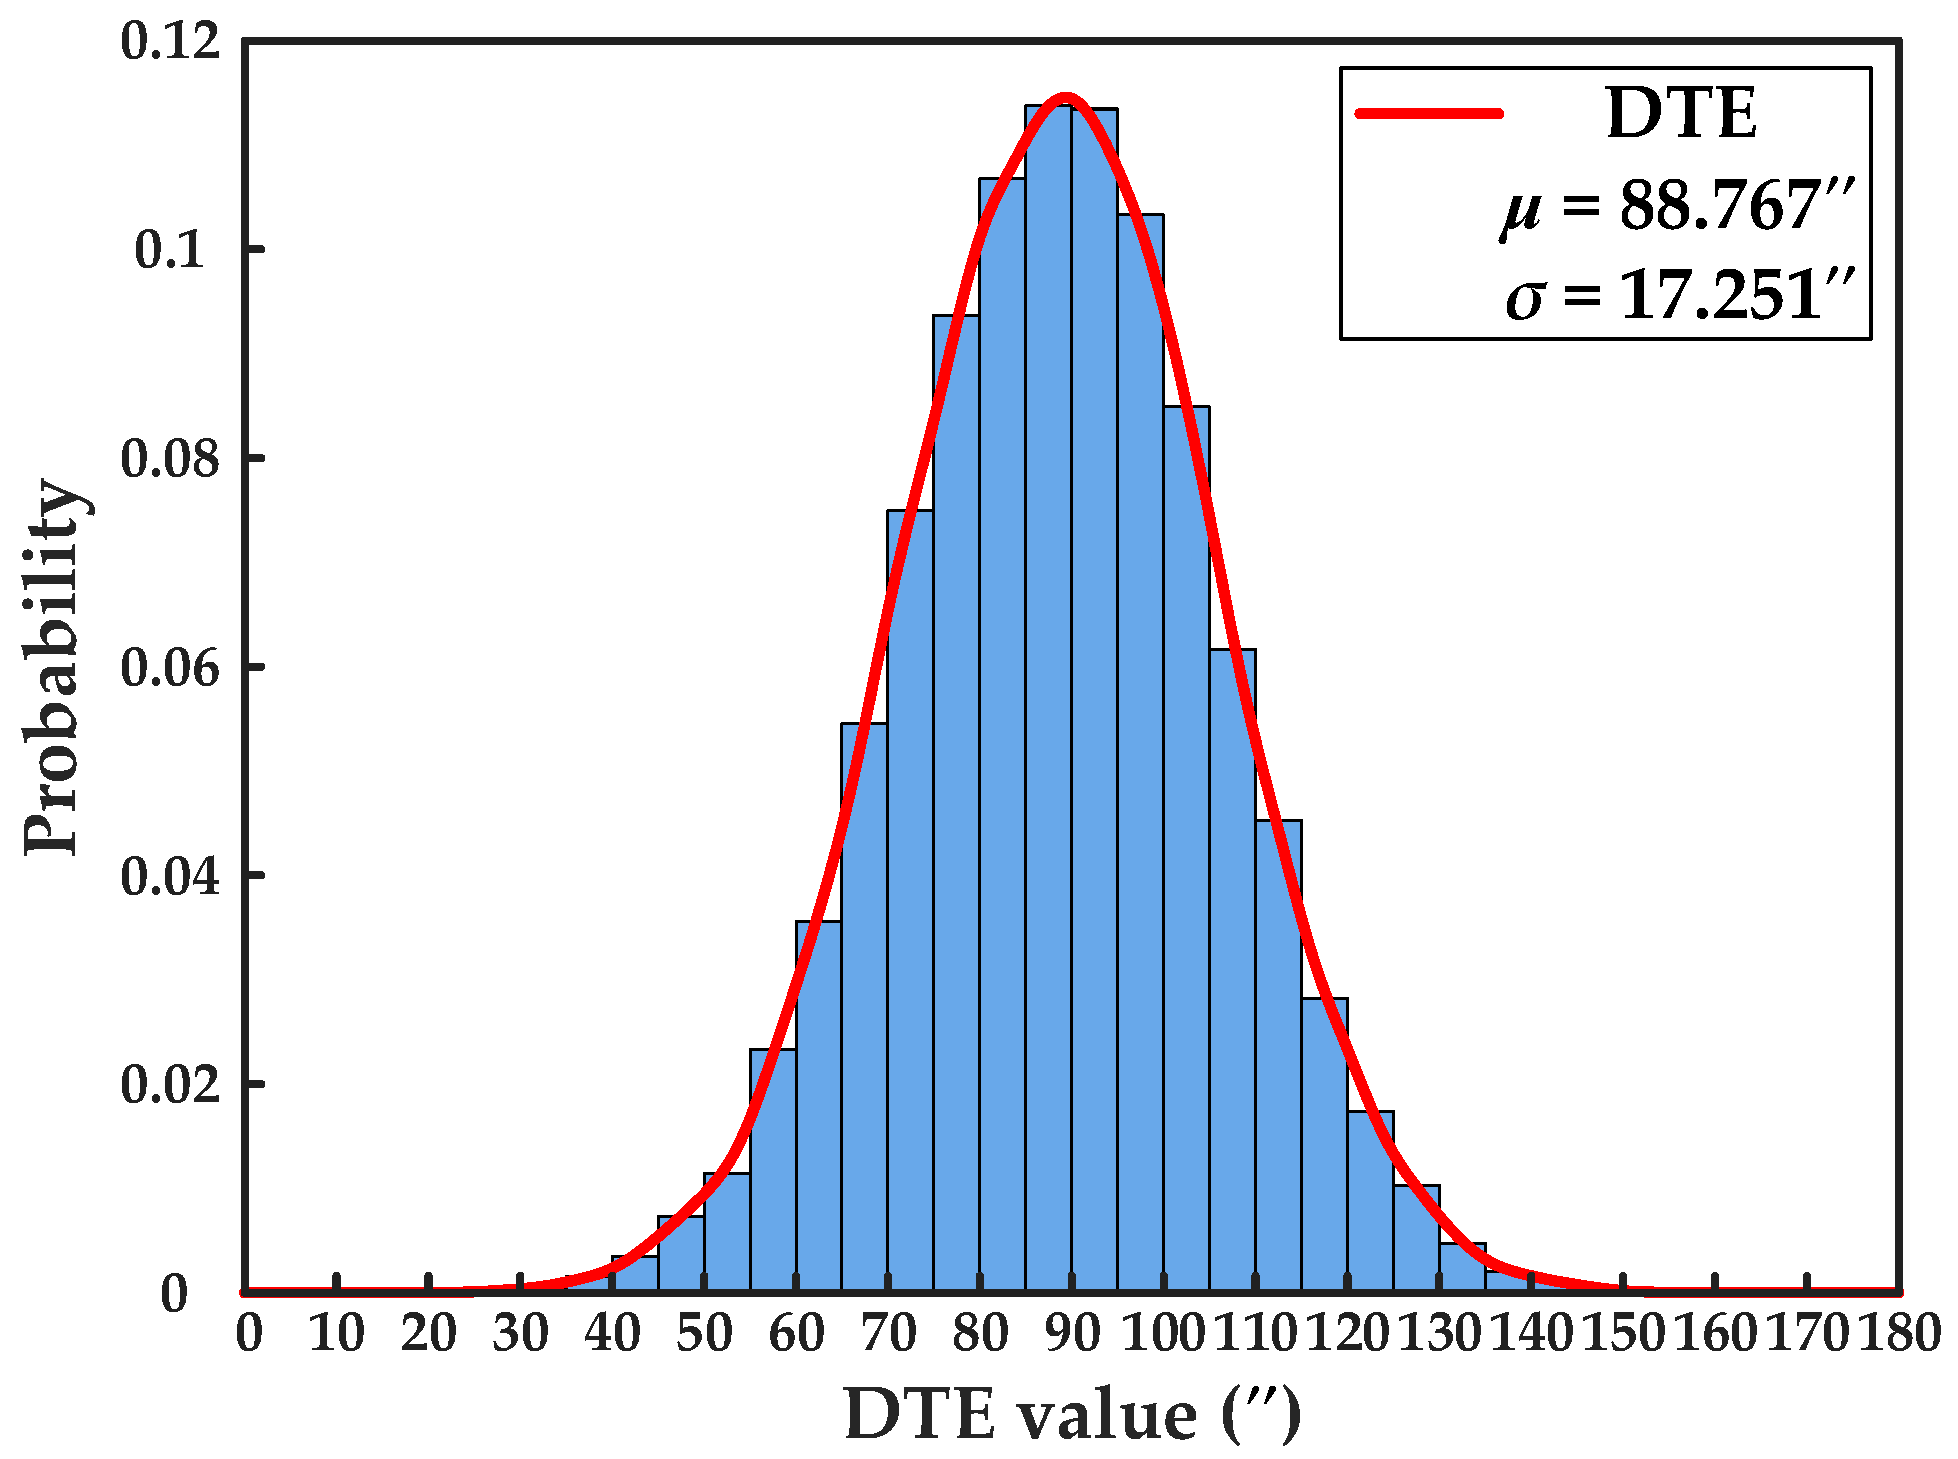
Based on the procedure illustrated in
Figure 7, the probability distribution of the DTE under the initial nominal design is obtained, as shown in
Figure 12.
Figure 12 indicates that the mean DTE is 88.767″, with a standard deviation of 17.251″.
To balance the transmission accuracy and robustness against disturbances of the harmonic drive, it is necessary to co-optimize the mean and standard deviation of the DTE. On the one hand, the mean DTE characterizes the average angular displacement error of the system under different parameter configurations. In multi-DOF manipulators, slight angular displacement errors at the joints are progressively amplified through the linkage geometry, directly affecting the positioning accuracy of the end-effector. Therefore, even a minor reduction in the mean DTE can effectively decrease the overall cumulative positioning error of the system. On the other hand, the standard deviation of the DTE reflects the error dispersion caused by parameter fluctuations. Optimizing the standard deviation aims to find a more robust dynamic parameter configuration. By effectively narrowing the distribution range of the DTE, the impact of parameter fluctuations on the system’s transmission performance can be mitigated.
4. Experimental Verification of the Chebyshev Surrogate Model
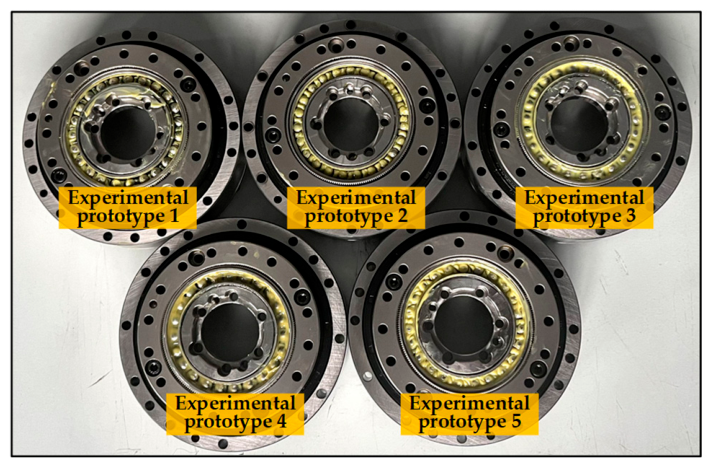
To verify the predictive performance of the Chebyshev surrogate model, an additional five prototypes of the HS-20-100 harmonic drive were employed for experimental validation, as shown in
Figure 13. The identification of the parameters
K,
Jin,
Bin, and
Bfc was conducted according to the method described in
Section 3. To obtain
θs, tests were performed under low-speed quasi-static conditions using Mode 1 of the experimental apparatus shown in
Figure 8. Prior to the experiments, the prototypes were operated at low speeds under specified lubrication and assembly conditions until a stable working state was achieved. During testing, the input end was driven by a servo motor while the load end remained unloaded, with the input speed set to
ωin = 10 r/min. Once the rotational speed and operating state stabilized, starting from a designated initial angular position, the
θs data were continuously recorded for three complete rotation cycles of the output end. The arithmetic mean of these data was then taken as the experimental value of
θs for the respective prototype. Ultimately, the identification results of the uncertain parameters for the five experimental prototypes are presented in
Table 6. Subsequently, by substituting these identified values into the established Chebyshev surrogate model, the predicted DTE values for each experimental prototype can be calculated.
Transmission error detection for the harmonic drive was conducted using the comprehensive performance test platform shown in
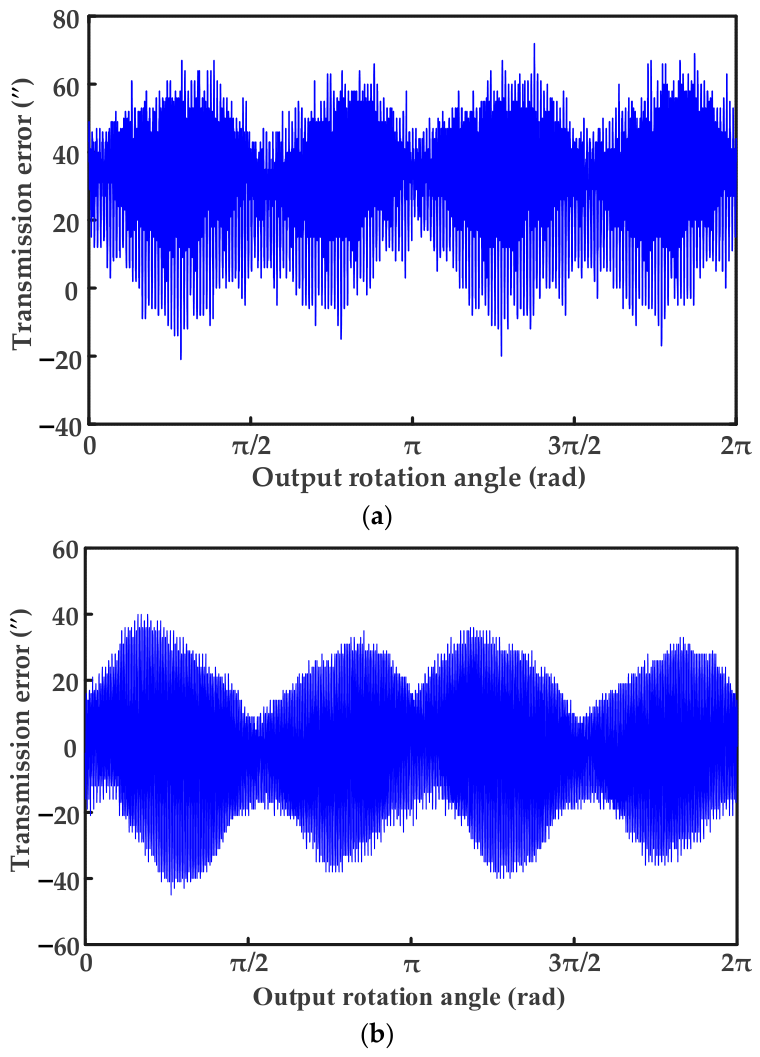
Figure 8. During the testing process, high-precision circular grating encoders (with a measurement accuracy of ±2 arcsec) at the input and output ends synchronously acquired angular displacement data at a sampling frequency of 1000 Hz. To eliminate high-frequency noise interference from the environment and electrical system, a zero-phase low-pass filter with a cutoff frequency of 100 Hz was employed to smooth the transmission error signal. Subsequently, a data segment spanning one complete cycle (i.e., a 2π rotation of the output end) of the prototype operating continuously and stably under rated conditions was extracted. The peak-to-peak value of the transmission error curve within this cycle (i.e., the absolute difference between the maximum positive deviation and the maximum negative deviation) was then extracted as the measured DTE value of the prototype. Taking experimental prototypes No. 1 and No. 2 as examples, their time-domain detection results of transmission error are shown in
Figure 14.
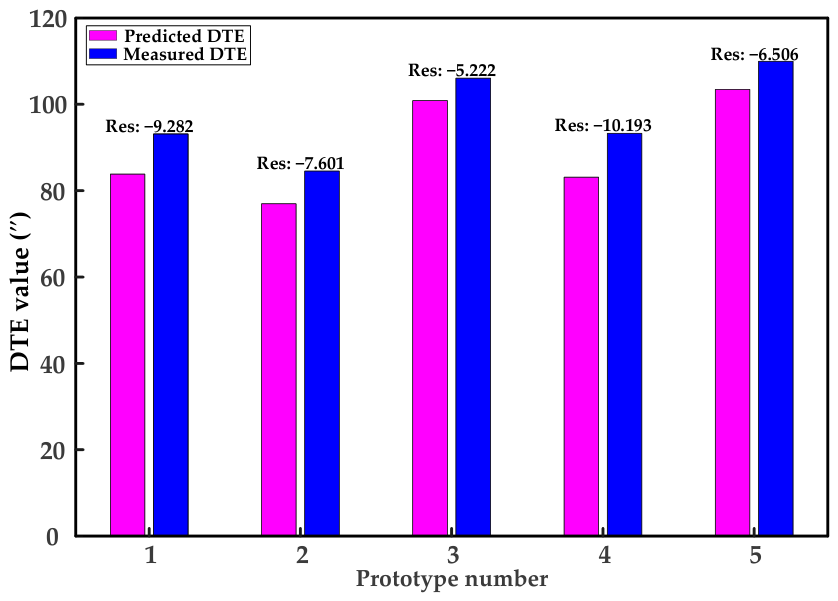
Figure 15 presents the comparison between the predicted and measured DTE values for the five experimental prototypes. Quantitative analysis indicates that the MAPE between the predicted and measured values is 8.14%, the MAE and RMSE are 7.761″ and 7.968″, respectively, and the Max Error is controlled within 10.193″. These metrics demonstrate that the established surrogate model exhibits good prediction accuracy for DTE.
Further analysis of the error distribution reveals a certain degree of underestimation in the model’s predictions. As shown in
Figure 15, the prediction residuals (Res) for all prototypes are negative. The mean error (ME) is −7.761″, and the 95% confidence interval of the mean error is [−10.265″, −5.257″]. Influenced by this systematic bias,
R2 is only 0.267. The primary reason for this underestimation bias is that the theoretical model struggles to capture unmeasurable complex factors under actual operating conditions. Although the model has incorporated core variables such as geometric errors, stiffness, and damping, phenomena existing in the physical system—such as local contact nonlinearity, time-varying friction fluctuations, and dynamic variations in assembly clearance—are difficult to accurately quantify. These objective factors induce additional incremental errors, causing the overall measured results to be higher than the theoretical predictions.
In conclusion, despite the systematic bias caused by the aforementioned unmeasurable factors, the current surrogate model still possesses reliable DTE prediction capability and good practical engineering value.
5. Robust Multi-Objective Optimization of DTE Based on Chebyshev–AMP–MOPSO Algorithm
This section conducts robust optimization targeting the statistical distribution characteristics of the DTE of harmonic drives, and proposes the Chebyshev–AMP–MOPSO algorithm, which integrates a state-driven weight adaptation based on diversity entropy and a pyramidal hierarchical dual-track search strategy. By utilizing diversity entropy to quantify the distribution state of the population, the algorithm adaptively adjusts the weights, reducing the tendency toward premature convergence and local optima. Simultaneously, leveraging a pyramidal hierarchical mechanism, it partitions the population into different levels to execute targeted dual-track search paths, ultimately achieving the optimization of both transmission accuracy and disturbance robustness.
5.1. Execution Process of the Chebyshev–AMP–MOPSO Algorithm
Taking the nominal value vector of the uncertain dynamic parameters,
U = [
K,
Jin,
Bin,
Bfc]
T, as the optimization variables, a bi-objective optimization model is constructed as follows:
where
F(
U) is the bi-objective fitness vector;
Umin and
Umax are the lower and upper bounds of the search space, respectively. The two sub-objectives are defined as
Objective 1 aims to minimize the mean value of the DTE distribution, μDTE, to improve transmission accuracy. Objective 2 aims to minimize the standard deviation, σDTE, to suppress transmission error fluctuations caused by multi-source parameter perturbations.
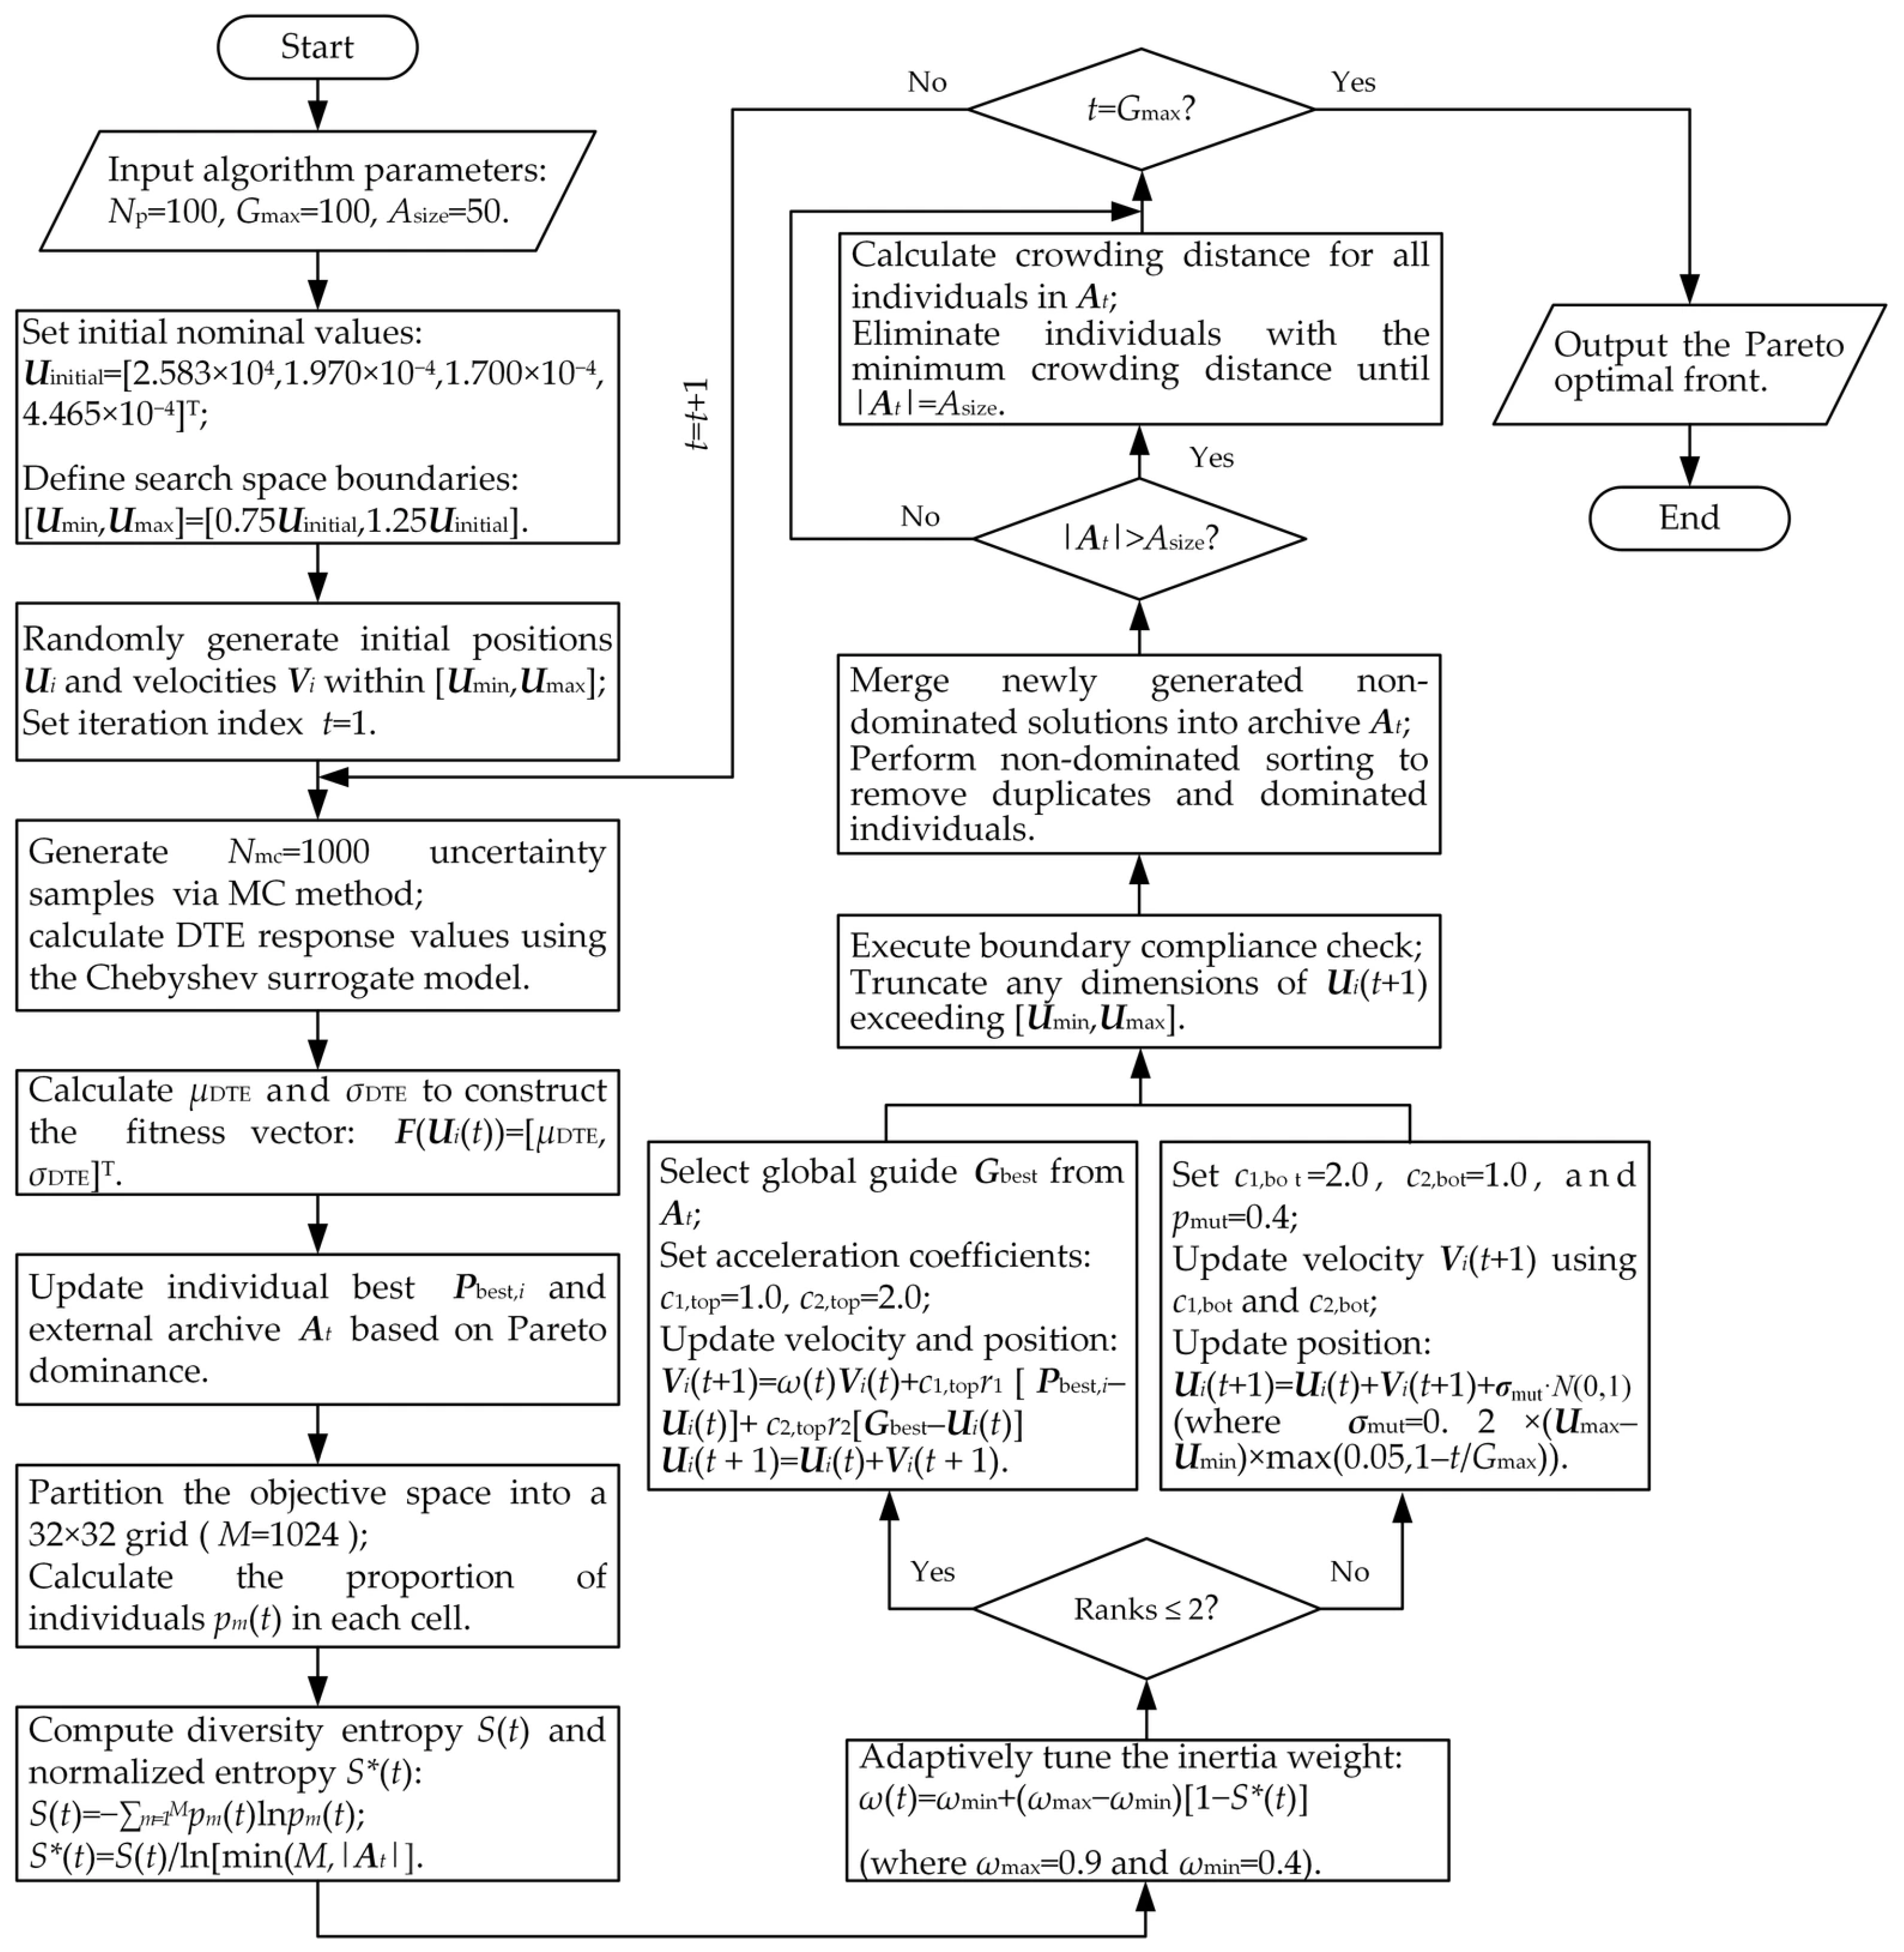
The execution flowchart of the Chebyshev–AMP–MOPSO algorithm is illustrated in
Figure 16, and the specific steps are detailed as follows:
Step 1: Initialization of population and parameter space. Set the population size Np = 100, the maximum number of iterations Gmax = 100, and the maximum capacity of the external non-dominated solution archive At as Asize = 50. The optimization search boundaries are set to ±25% of the nominal values. The position vector Ui and velocity vector Vi of the initial population are randomly generated within the bounds, and the current iteration index is set to t = 1.
Step 2: Parameter space sampling and fitness evaluation. A total of Nmc = 1000 uncertainty parameter sample points are drawn using the MC method. For each particle Ui(t) generated in the current generation, these sample points are substituted into the Chebyshev surrogate model to calculate 1000 sets of DTE response values. The statistical features μDTE and σDTE of this response sample set are evaluated to construct the bi-objective fitness vector F(Ui(t)) for the particle. The individual best solution Pbest,i is determined and updated based on the Pareto dominance relationship, and the archive At is maintained.
Step 3: State-driven weight adaptation based on grid diversity entropy. A diversity entropy mechanism in the objective space is introduced to dynamically monitor the distribution of the Pareto front. The current objective space is partitioned into a 32 × 32 grid matrix, yielding a total of
M = 1024 grid cells. The proportion of individuals
pm(
t) in the current
At falling into the
m-th grid cell is counted, and the diversity entropy of the population is calculated as
Considering the maximum capacity limit of the external archive, a dynamic bound is employed when calculating the normalized entropy value:
Subsequently, the inertia weight
ω(
t) for the next generation is adaptively adjusted based on the distribution state of the current archived solution set:
where the maximum inertia weight
ωmax = 0.9 and the minimum inertia weight
ωmin = 0.4. This mechanism allows
ω(
t) to autonomously increase when the population tends towards premature convergence and lacks diversity, thereby enhancing the global exploration capability of individuals and effectively escaping local optima.
Step 4: Pyramidal hierarchical dual-track search strategy. Based on the Pareto rank obtained from non-dominated sorting, the population is dynamically partitioned into a hierarchical pyramid structure, and a dual-track search path with distinct division of labor is implemented.
Top layer (exploitation layer, ranks ≤ 2): Responsible for refined convergence in the superior regions at the front. Particles in this layer are assigned a low individual cognitive factor (
c1,top = 1.0) and a high social experience factor (
c2,top = 2.0). Their velocity and position update formulas are as follows:
where
Gbest is the global guide selected from
At;
r1 and
r2 are random numbers uniformly distributed in the interval [0, 1].
Bottom layer (exploration layer, ranks > 2): Responsible for broad search in the global unknown space. They are assigned a high individual cognitive factor (
c1,bot = 2.0) and a low social experience factor (
c2,bot = 1.0). The velocity update form is identical to Equation (34). During position updating, to expand the search coverage, a Gaussian mutation operator is introduced with a fixed probability
pmut = 0.4 to perturb the position vector:
where
N(0, 1) is a random number vector from the standard normal distribution. The mutation step size vector
σmut shrinks linearly with the iteration process to ensure convergence in the later stages of the algorithm, calculated as
After all particle positions are updated, boundary constraint checks are executed. Dimensions exceeding the bounds [Umin, Umax] are truncated.
Step 5: External archive maintenance and crowding distance truncation. The newly generated non-dominated solutions are merged into At, and non-dominated sorting is re-performed to remove duplicates. If the number of solutions in At exceeds the upper limit Asize, the crowding distance of each solution in the archive is calculated within the two-dimensional objective space, and individuals with the smallest distances are eliminated one by one to ensure the uniform spatial distribution of the Pareto front. If the maximum number of iterations has not been reached, return to Step 2; otherwise, the algorithm terminates and outputs the bi-objective Pareto optimal front.
5.2. Optimization Results and Performance Comparative Analysis of Chebyshev–AMP–MOPSO
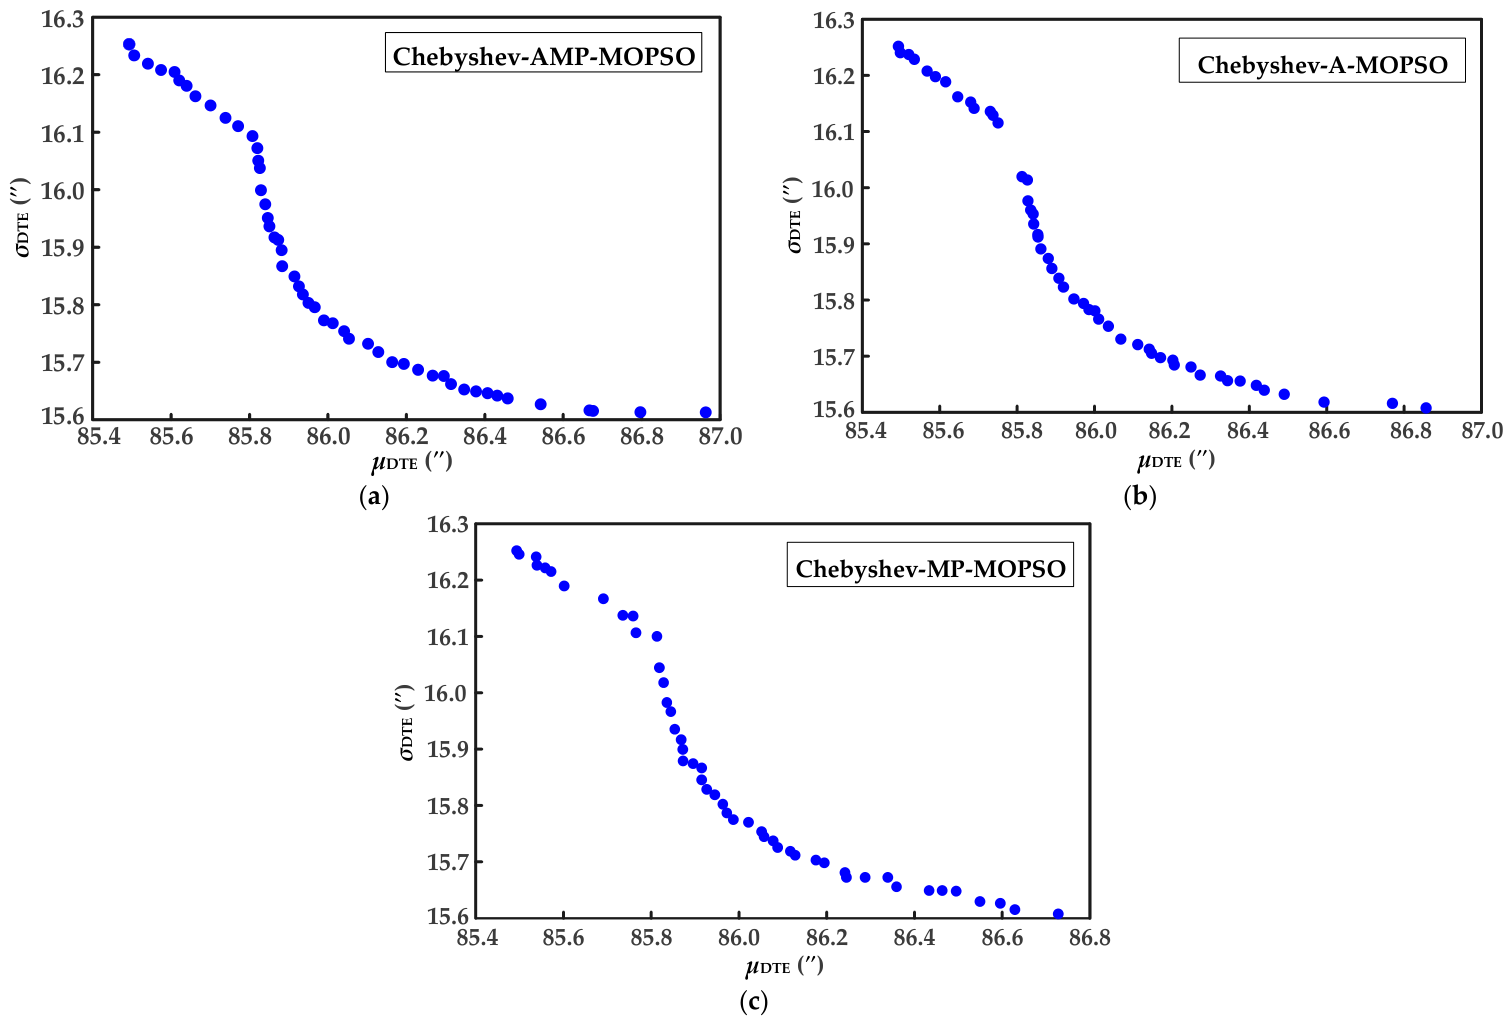
The Chebyshev–AMP–MOPSO algorithm is employed to conduct bi-objective robust optimization for the DTE of the harmonic drive, and the finally obtained Pareto optimal front is shown in
Figure 17a. This algorithm obtains a series of continuous and uniformly distributed non-dominated solutions, effectively balancing transmission accuracy and disturbance robustness.
To verify the synergistic advantages of the diversity entropy state-driven weight adaptation and pyramidal hierarchical dual-track search strategies, an ablation comparative experiment is conducted: the Chebyshev–A–MOPSO algorithm retaining only the state-driven weight strategy (
Figure 17b) and the Chebyshev–MP–MOPSO algorithm retaining only the hierarchical dual-track search strategy (
Figure 17c) are constructed respectively.
As can be seen from
Figure 17b, due to the lack of refined dual-track exploitation in the superior regions of the front, a distinct solution set gap appears in the middle section of the front. As can be seen from
Figure 17c, due to the lack of quantification and feedback regulation of the distribution state in the objective space, some solutions aggregate in local regions, and the overall distribution uniformity of the front decreases. The above comparison supports the complementary contributions of the two strategies.
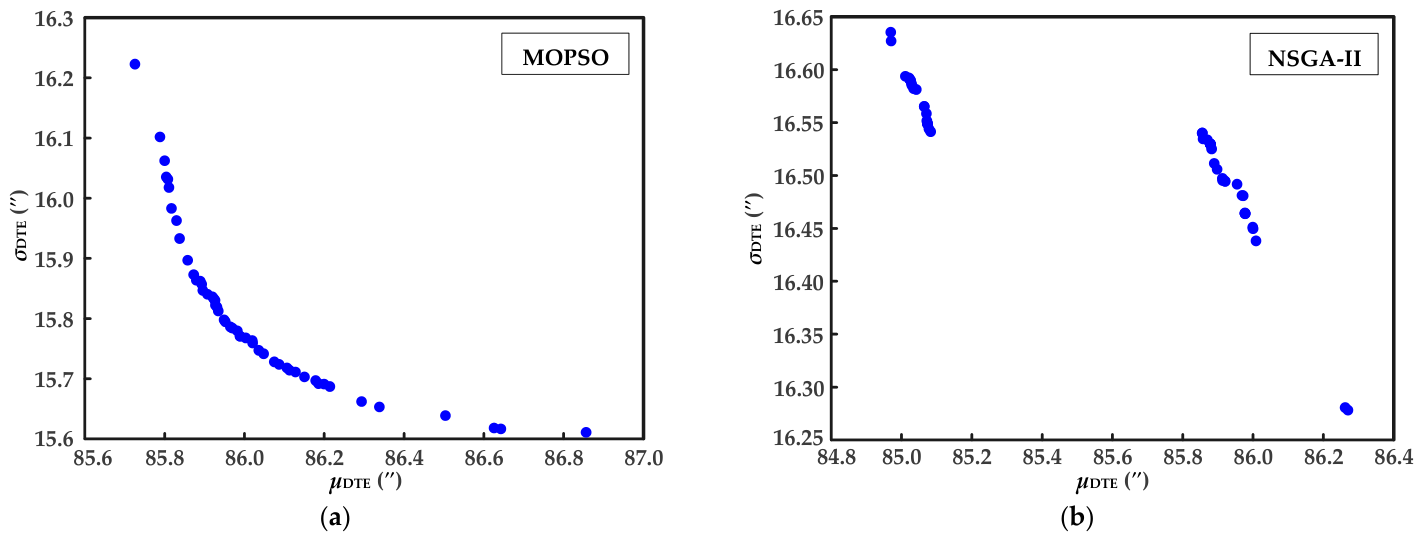
To further quantitatively evaluate the comprehensive optimization performance of the Chebyshev–AMP–MOPSO algorithm, comparative experiments are conducted against the basic MOPSO algorithm and the classic NSGA-II algorithm. The three algorithms are all run independently 20 times. The statistical results of the evaluation metrics are shown in
Table 7, and the Pareto fronts of the two comparative algorithms are shown in
Figure 18.
Intuitive comparison reveals that the fronts obtained by these two comparative algorithms both exhibit obvious local aggregation or solution set gap phenomena. In terms of the Inverted Generational Distance (IGD), which measures the convergence and diversity of the algorithm, the calculated value of the Chebyshev–AMP–MOPSO algorithm is 0.0180, which decreases by approximately 79.9% and 91.7% compared to MOPSO and NSGA-II, respectively; in terms of the Spacing metric, which measures the distribution uniformity of the front, this algorithm also achieves the minimum value (0.0235). The above results effectively confirm the role of the proposed strategies in improving the front quality. Furthermore, thanks to the substitution of the Chebyshev surrogate model for highly time-consuming dynamic simulations, the Chebyshev–AMP–MOPSO algorithm essentially matches the comparative algorithms in average running time (22.28 s) while enhancing the solution quality, thereby taking computational efficiency into account.
5.3. Multi-Attribute Decision-Making and Result Analysis Based on Weighted Utopia Distance
To accurately extract the optimal parameter configuration that balances both the mean and standard deviation of the transmission error from the Pareto non-dominated solution set obtained by the Chebyshev–AMP–MOPSO algorithm, this section introduces the weighted Utopia distance compromise programming method for multi-attribute decision-making. This approach aims to identify the compromise solution with the maximum global comprehensive utility. The specific calculation steps are as follows:
Step 1: Objective data extraction. The bi-objective vectors of
m = 50 Pareto optimal solutions are extracted from the archive
At:
Step 2: Min-max normalization. To eliminate dimensional effects, the objective values are normalized into the [0, 1] space (0 and 1 correspond to the best and worst limits of the solution set, respectively):
If max(fj) − min(fj) = 0, then let (i) = 0.
Step 3: Ideal point and weight definition. In the normalized space, the coordinate origin is defined as the theoretical Utopian ideal point
F* = [0, 1]
T. The normalized weight vector
W is defined as
Step 4: Weighted Euclidean distance calculation and solution selection. The weighted Euclidean distance
di from each non-dominated solution to the ideal point is calculated as
Based on the minimum distance criterion, the optimal solution index
i* is determined, and the corresponding nominal value vector
Uopt along with its fluctuation interval [
UtolLower,
UtolUpper] are inversely extracted:
Considering different design preferences regarding transmission accuracy and robustness, the weight vector
W is configured differently. Three typical decision preferences are defined: the accuracy-first preference (
WPF = [0.9, 0.1]
T), the balanced preference (
WBAL = [0.5, 0.5]
T), and the robustness-first preference (
WRF = [0.1, 0.9]
T).
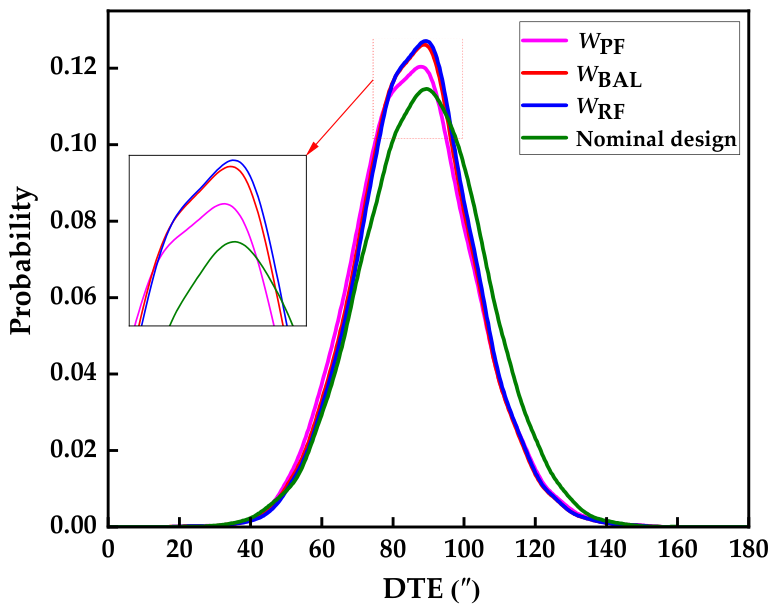
Table 8 compares the optimization indicators between the initial design and the three decision preferences.
Figure 19 presents the corresponding comparison of the DTE probability distribution curves.
As shown in
Table 8 and
Figure 19, compared to the initial design, the optimization results under all three decision preferences effectively improve the transmission accuracy and robustness of the system. Specifically, the optimization process under the accuracy-first preference focuses on reducing the mean, achieving a mean reduction of 3.67%; the robustness-first preference emphasizes suppressing error fluctuations, yielding a standard deviation reduction of 9.36%; and the balanced preference strikes a favorable balance between improving the mean and the standard deviation. The probability distribution curves and their local peak differences under the different decision preferences in
Figure 19 intuitively confirm the aforementioned trade-off patterns corresponding to the varying weight configurations.
It should be noted that although the common random numbers (CRN) strategy was introduced during optimization iterations to suppress sampling noise, in order to further verify the reliability of the optimal solutions obtained under the original sampling size (Nmc = 1000), this paper conducted an independent re-evaluation of the optimal parameter configurations under three decision preferences using 100,000 samples based on the Chebyshev surrogate model. The results show that the re-evaluated DTE mean and standard deviation are in high agreement with the original optimization results (the relative error of the mean is less than 0.5%, and the absolute deviation of the standard deviation is less than 0.3″), and the 95% confidence interval of the mean is relatively narrow (approximately ±0.1″). This testing result effectively verifies the statistical reliability and numerical stability of the optimization results in this paper.
Although the relative reductions in the indicators in
Table 8 are numerically modest, they still hold practical engineering significance in the field of precision transmission. First, the DTE of the harmonic drive under the initial nominal design is already at the arc-second level, falling strictly into the category of precision transmission; given this high baseline, further significant reductions in DTE are highly challenging. Second, as a motion transmission component, even a marginal reduction in DTE contributes to minimizing the positioning error at the system’s output end. Furthermore, without requiring any macro-structural redesign, this study achieves improved transmission accuracy and tighter error fluctuations simply by optimizing the dynamic parameters, thereby enhancing the overall robust performance of the harmonic drive.
Table 9 lists the optimal nominal values and their corresponding fluctuation intervals for each dynamic parameter. It should be noted that the targets of optimization in this study are the macroscopic dynamic parameters, and the optimization results provide a theoretical reference for the detailed component design and assembly processes of the harmonic drive. In actual manufacturing and assembly, the regulation of the aforementioned parameters must be realized through specific geometric features and process parameters. For instance,
K can be matched by adjusting the wall thickness of specific sections of the FS or by optimizing the micro-modification of the tooth profile;
Jin can be controlled by adjusting the local structural dimensions of the WG; and
Bin and
Bfc depend on the adjustment of the assembly preload among the FB, CS, and FS, as well as the selection of the lubricating grease. Therefore, the fluctuation intervals in
Table 9 represent the prescribed parameter-variation bands used for robustness evaluation around the selected nominal designs.
To verify the influence trend of the deviation degree between the actual dynamic parameters of the harmonic drive prototypes and the theoretical optimal configuration on the measured DTE mean, a comparative analysis was conducted using five experimental prototypes whose parameter identification was completed in
Section 4. Here, the parameter deviation degree
Di is defined to quantitatively characterize the relative deviation level of the actual dynamic parameter vector
Ui of the
i-th prototype relative to the theoretical optimal configuration
Uopt. Its calculation formula is as follows:
where
j = 1,2,3,4 correspond to parameters
K,
Jin,
Bin, and
Bfc, respectively. According to the optimization results under the WPF decision preference,
Uopt is
K = 3.229 × 10
4 N·m/rad,
Jin = 1.496 × 10
−4 kg·m
2,
Bin = 1.891 × 10
−4 N·m·s/rad, and
Bfc = 4.968× 10
−4 N·m·s/rad.
Substituting the actual parameters of the five experimental prototypes (see
Table 6) into Equation (42) yields the
Di values for each prototype: 0.367 (No. 1), 0.379 (No. 2), 0.371 (No. 3), 0.474 (No. 4), and 0.365 (No. 5). Based on the comparison of measured data, the No. 5 prototype with the smallest
Di exhibits the lowest measured DTE mean among the five prototypes, whereas the No. 4 prototype with the largest
Di exhibits the highest measured DTE mean. This comparative result indicates that the closer the prototype parameters are to the theoretical optimal configuration, the lower the measured DTE mean, thereby effectively validating the rationality of the optimization scheme in this paper.
6. Conclusions
This paper proposes an efficient modeling and robust multi-objective collaborative optimization method for the dynamic transmission error (DTE) of harmonic drives under multi-source probabilistic uncertain parameters. The computational efficiency of the dynamic response evaluation is improved by constructing a Chebyshev surrogate model, and the collaborative optimization of the DTE mean and standard deviation under different decision preferences is achieved using the Chebyshev–AMP–MOPSO algorithm. The main conclusions are as follows:
1. DTE uncertainty modeling: A Chebyshev polynomial surrogate model is constructed by combining the measured static transmission error (STE) probability model and the system dynamic equations. In the independent test within the parameter space, the third-order (k = 3) model exhibits excellent generalization accuracy, with a coefficient of determination (R2) reaching 0.998. Compared with the original dynamic model, the surrogate model reduces the computation time of a single evaluation from 0.147 s to 0.000003 s, achieving an acceleration ratio of 49,000. Furthermore, when executing 1000 Monte Carlo evaluations, it achieves a batch-evaluation acceleration ratio of 42,943. This substantially reduces the computational cost of conventional numerical integration methods in dynamic response evaluation.
2. Validation of the surrogate model: Experimental validation was conducted based on five HS-20-100 harmonic drive prototypes. The comparative analysis shows that the mean absolute percentage error (MAPE) between the predicted values of the surrogate model and the measured values of the prototypes is 8.14%, the mean absolute error (MAE) is 7.761″, the root mean square error (RMSE) is 7.968″, and the maximum absolute error (Max Error) is controlled within 10.193″. This indicates that the surrogate model possesses reliable DTE predictive capability and can satisfy the requirements for engineering evaluations.
3. Optimization performance of the Chebyshev–AMP–MOPSO algorithm: Aiming at the dual-objective collaborative optimization problem of the DTE mean and standard deviation, the proposed algorithm integrates a diversity entropy state-driven adaptive weight and a pyramid-hierarchical dual-track search strategy. Compared with the classical MOPSO and NSGA-II algorithms, the inverted generational distance (IGD) of the proposed algorithm is reduced to 0.0180, and the Spacing metric is reduced to 0.0235, which effectively improves the convergence of the Pareto optimal front and the distribution uniformity of the solution set.
4. Parameter optimization under different decision preferences: Based on the weighted Utopia distance method, parameter optimization for the initial nominal design (mean of 88.767″, standard deviation of 17.251″) was conducted under three typical preferences. Under the accuracy-first preference, the DTE mean is reduced by 3.67%; under the robustness-first preference, the standard deviation is reduced by 9.36%; and the balanced preference achieves improvements in both the mean and the standard deviation. The independent re-evaluation results based on a large sample of 100,000 runs show that the relative error of the optimized mean is less than 0.5%, verifying the numerical stability of the optimization results.
5. Physical prototype validation of the optimization scheme: A comparative test was conducted based on five experimental prototypes. The results show that the deviation (Di) of the actual dynamic parameters of the prototypes relative to the theoretical optimal configuration exhibits a consistent corresponding trend with their measured DTE means: Prototype No. 5 with the minimum deviation (Di = 0.365) exhibits the lowest measured DTE mean, while Prototype No. 4 with the maximum deviation (Di = 0.474) exhibits the highest measured DTE mean. This experimental performance is consistent with the theoretical optimization expectations of this study.