2.1. Study Area
Pingtan (25°15′–25°45′ N, 119°32′–120°10′ E) lies off the central coast of Fujian Province on the western side of the Taiwan Strait. Haitan Island, the main island of Pingtan, covers 267.13 km
2 and is the fifth-largest island in China. The island has generally low relief and is dominated by marine depositional plains [
23]. It has a warm, humid subtropical maritime monsoon climate. Vegetation is dominated by mixed stands of Casuarina equisetifolia and Acacia confusa, and its diverse dunes provide favorable conditions for coastal recreation.
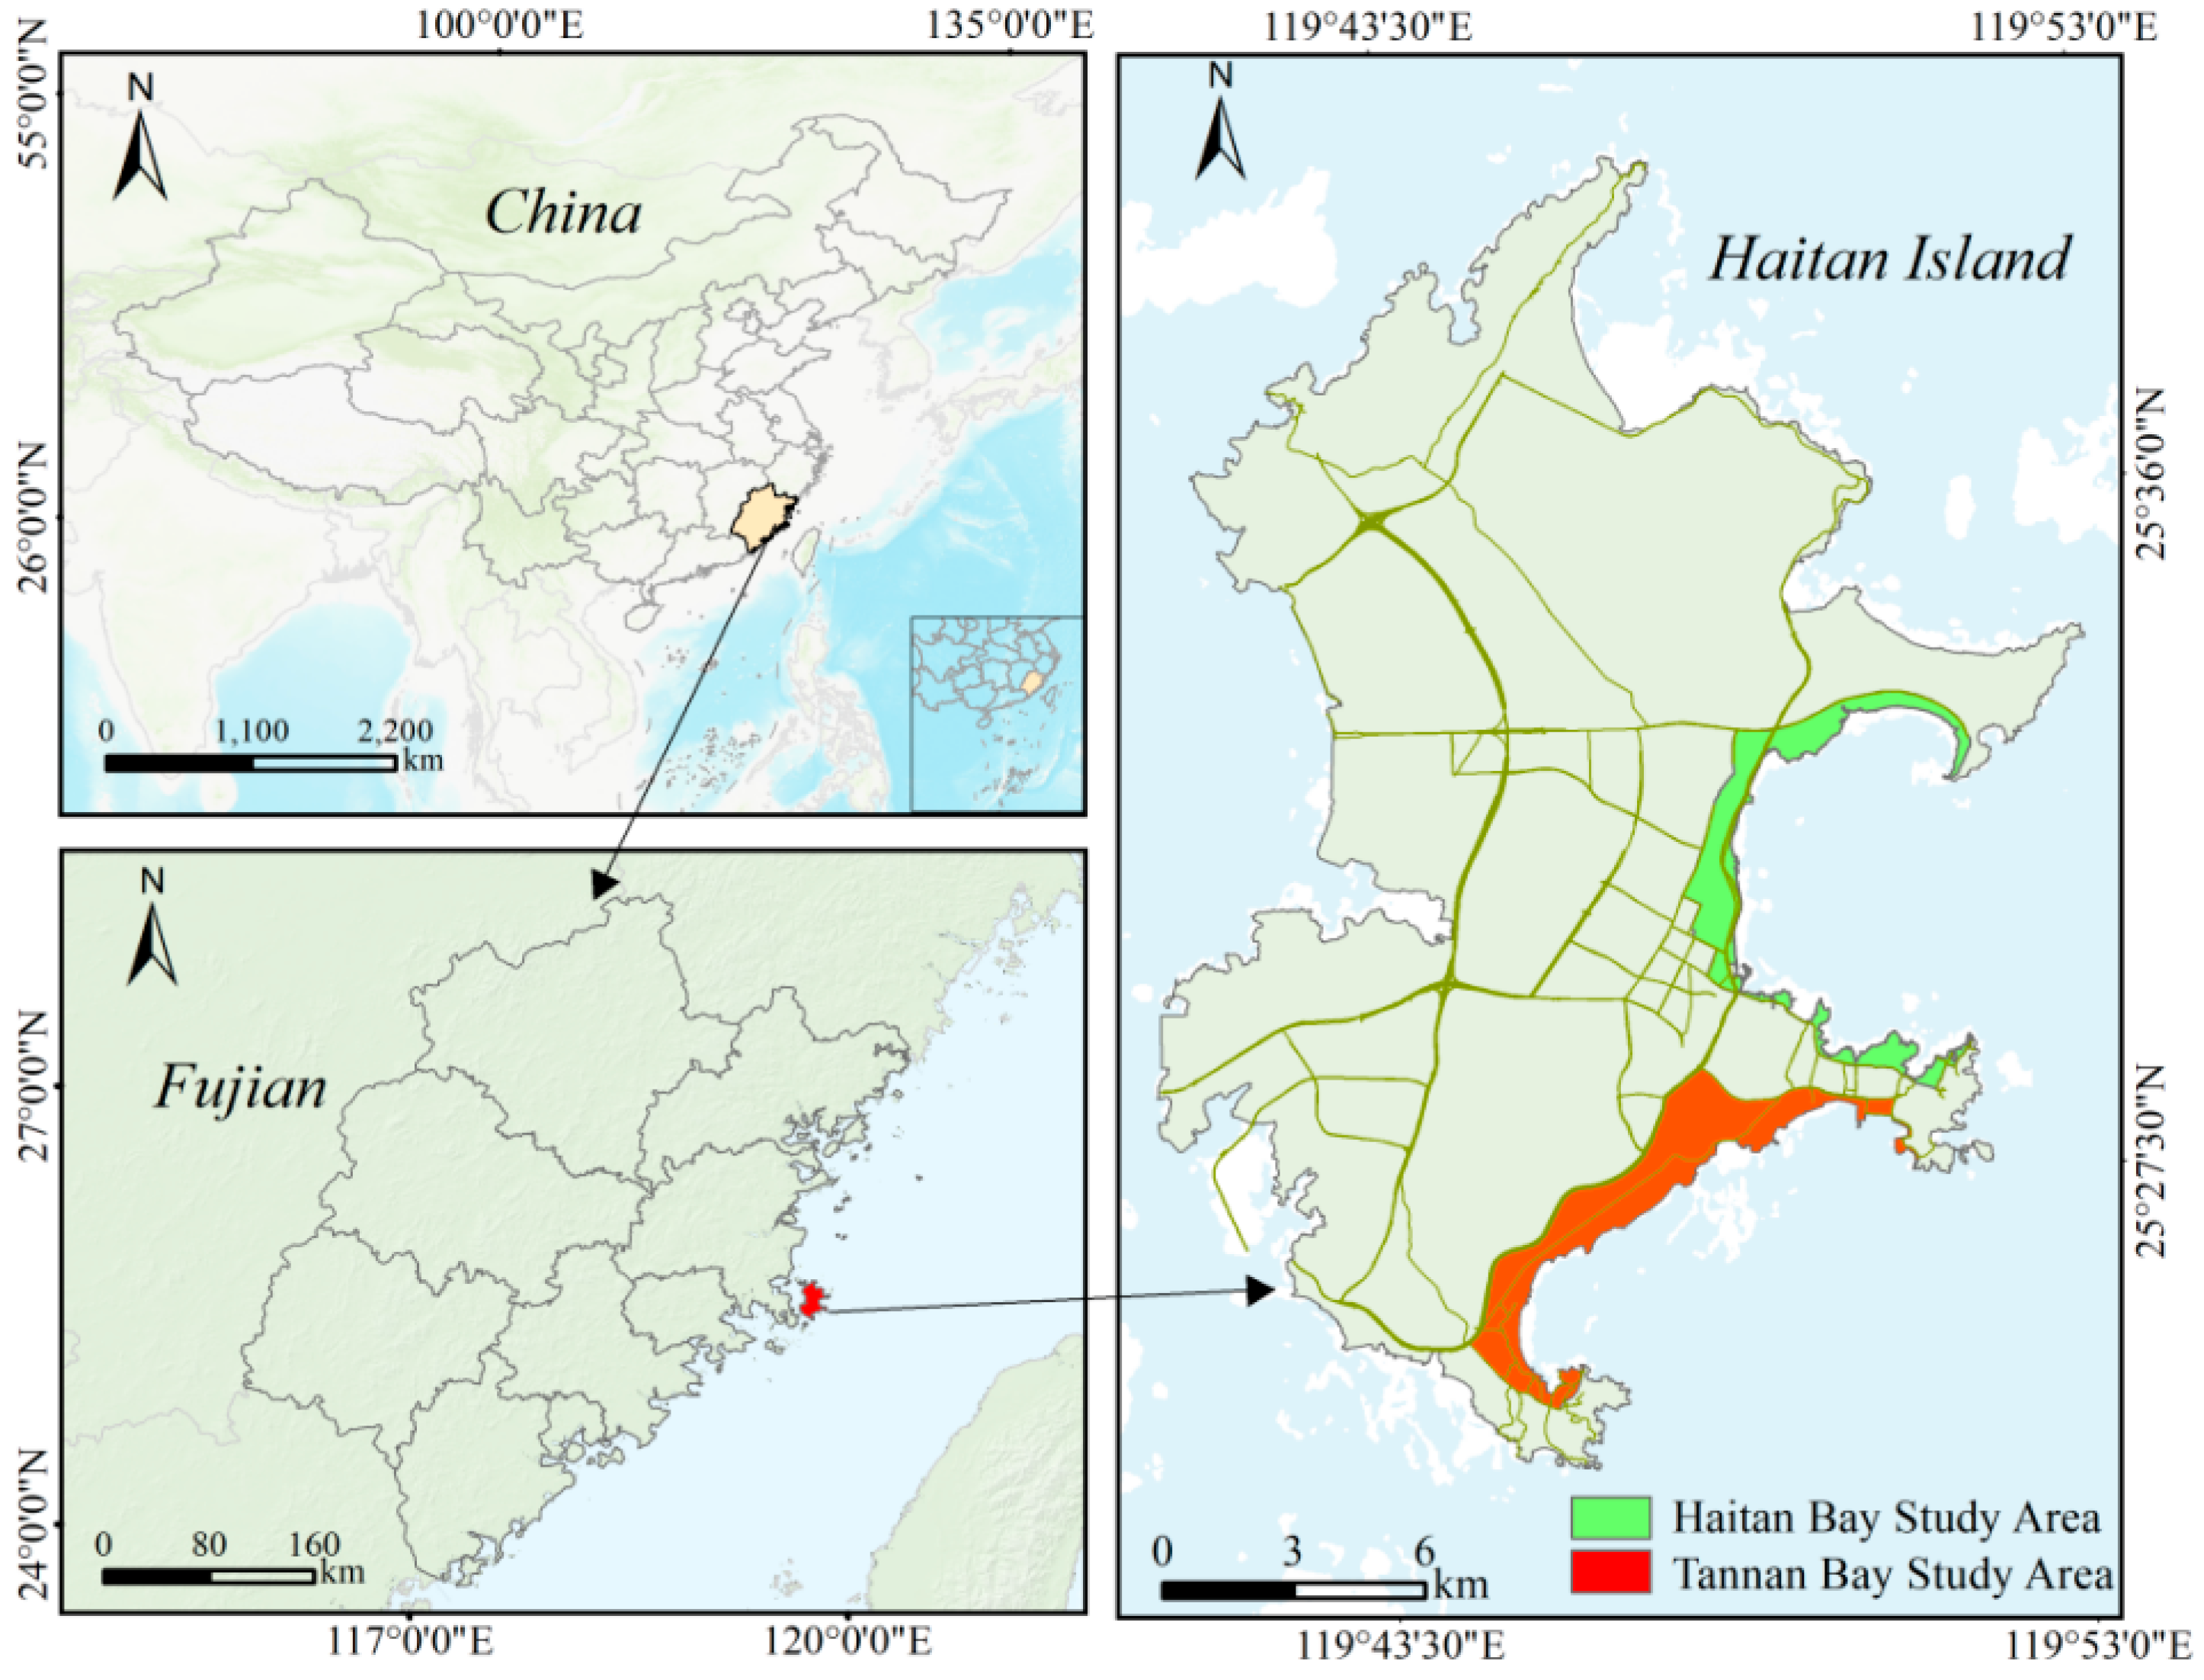
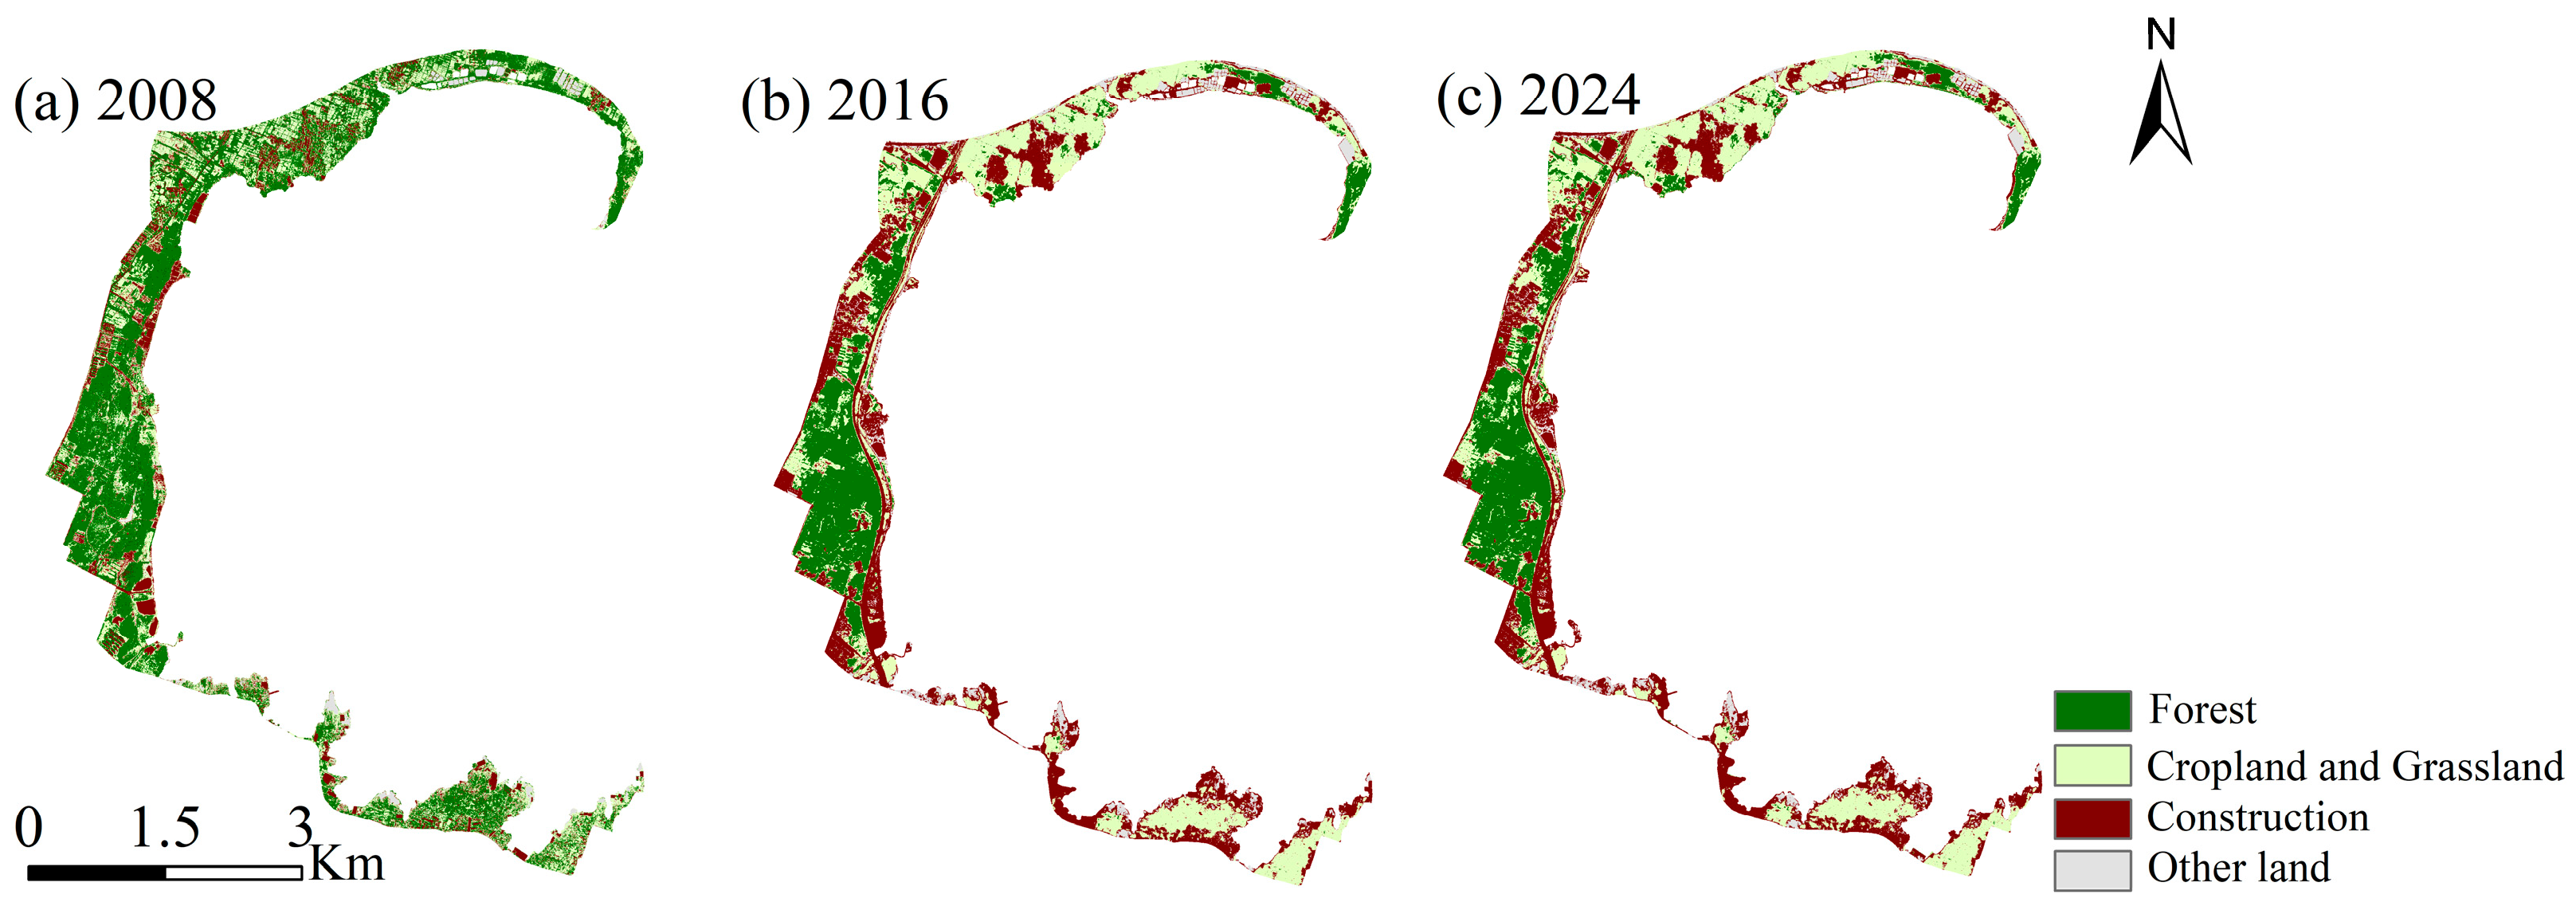
This study selected the bay-adjacent terrestrial areas of Haitan Bay and Tannan Bay as comparative study units (
Figure 1). Haitan Bay and Tannan Bay have relatively distinct functional roles in local spatial planning. The Master Plan of Haitan Scenic and Historic Area (2017–2030): Planning Explanatory Report, in coordination with the Master Plan of Pingtan Comprehensive Experimental Zone (2011–2030), designates the Tannan Bay and Haitan Bay clusters within the coastal tourism and recreation space of the main island [
24]. The Haitan Bay study area covers 8.44 km
2 and was a core area of early development on Pingtan Island. Its built-up areas are relatively concentrated, and it has a long history of human use. Its landscape pattern is characterized by intensive anthropogenic disturbance and shoreline artificialization. The Tannan Bay study area covers 10.98 km
2 and was developed later. It features high-quality beaches, relatively well-preserved coastal shelterbelts, and a favorable ecological background. It therefore provides a representative setting for studying landscape evolution under conflicts between conservation and development [
25].
2.2. Data Sources and Processing
To ensure spatial comparability between the two bays and across periods, this study applied a consistent rule to delineate the bay-adjacent terrestrial areas. On the landward side, the island ring road and connected major roads formed a closed boundary, while the 2019 baseline coastline was used uniformly as the seaward boundary. The Master Plan of Haitan Scenic and Historic Area (2017–2030): Planning Explanatory Report uses roads, identifiable landmarks, and physical features as boundary references in spatial delineation and, in some locations, uses the island ring road to define scenic-area boundaries [
26]. The Territorial Spatial Ecological Restoration Plan of Pingtan Comprehensive Experimental Zone (2021–2035) further identifies the island ring road as the backbone of the “one-ring” transport–ecological corridor linking major coastal scenic areas and distinctive villages and towns, including Haitan Bay and Tannan Bay [
27]. Based on these local spatial-organization characteristics, the island ring road and adjacent major roads provide a continuous, clear, and reproducible landward spatial reference for the two study units. The 2008, 2016, and 2024 land-use data and the 2035 scenario simulations used this fixed study extent, while the 2019 baseline coastline was used to standardize the spatial boundary across periods. Socioeconomic parameters were derived mainly from the Pingtan Statistical Yearbook 2024 and the 2024 Statistical Bulletin on National Economic and Social Development of the Pingtan Comprehensive Experimental Zone. Additional sources were the Territorial Spatial Master Plan of the Pingtan Comprehensive Experimental Zone (2018–2035) and its Report on Sustainable Ecological and Environmental Development (2018–2020). The 2025 Statistical Bulletin on National Economic and Social Development of Fujian Province was also used. The 2025 statistics were used mainly to parameterize future scenarios. Other data sources are listed in
Table 1.
Land-use classification was based on three 2 m resolution imagery datasets, all provided by the Island Research Center, Ministry of Natural Resources. The 2008 dataset comprised aerial orthophotographs acquired from 6 to 15 March 2008; the 2016 dataset comprised Gaofen-1 (GF-1) PMS imagery acquired on 19 September 2016; and the 2024 dataset comprised Gaofen-6 (GF-6) PMS orthophotographs acquired on 19 July 2024. Classification accuracy assessment was conducted using same-year high-resolution reference imagery that had not been used in the land-use classification process. The reference imagery for 2016 and 2024 consisted of Google Earth Pro historical images dated 27 March 2016 and 18 December 2024, respectively; for 2008, a 2 m historical remote-sensing image from May 2008 provided by the Island Research Center, Ministry of Natural Resources, was used. The three imagery datasets used for land-use classification were projected to WGS 1984 UTM Zone 50N and geometrically registered in ArcGIS 10.8, yielding a root mean square error of 0.97 m. The images were then clipped to the common study boundaries for land-use classification and landscape pattern analysis.
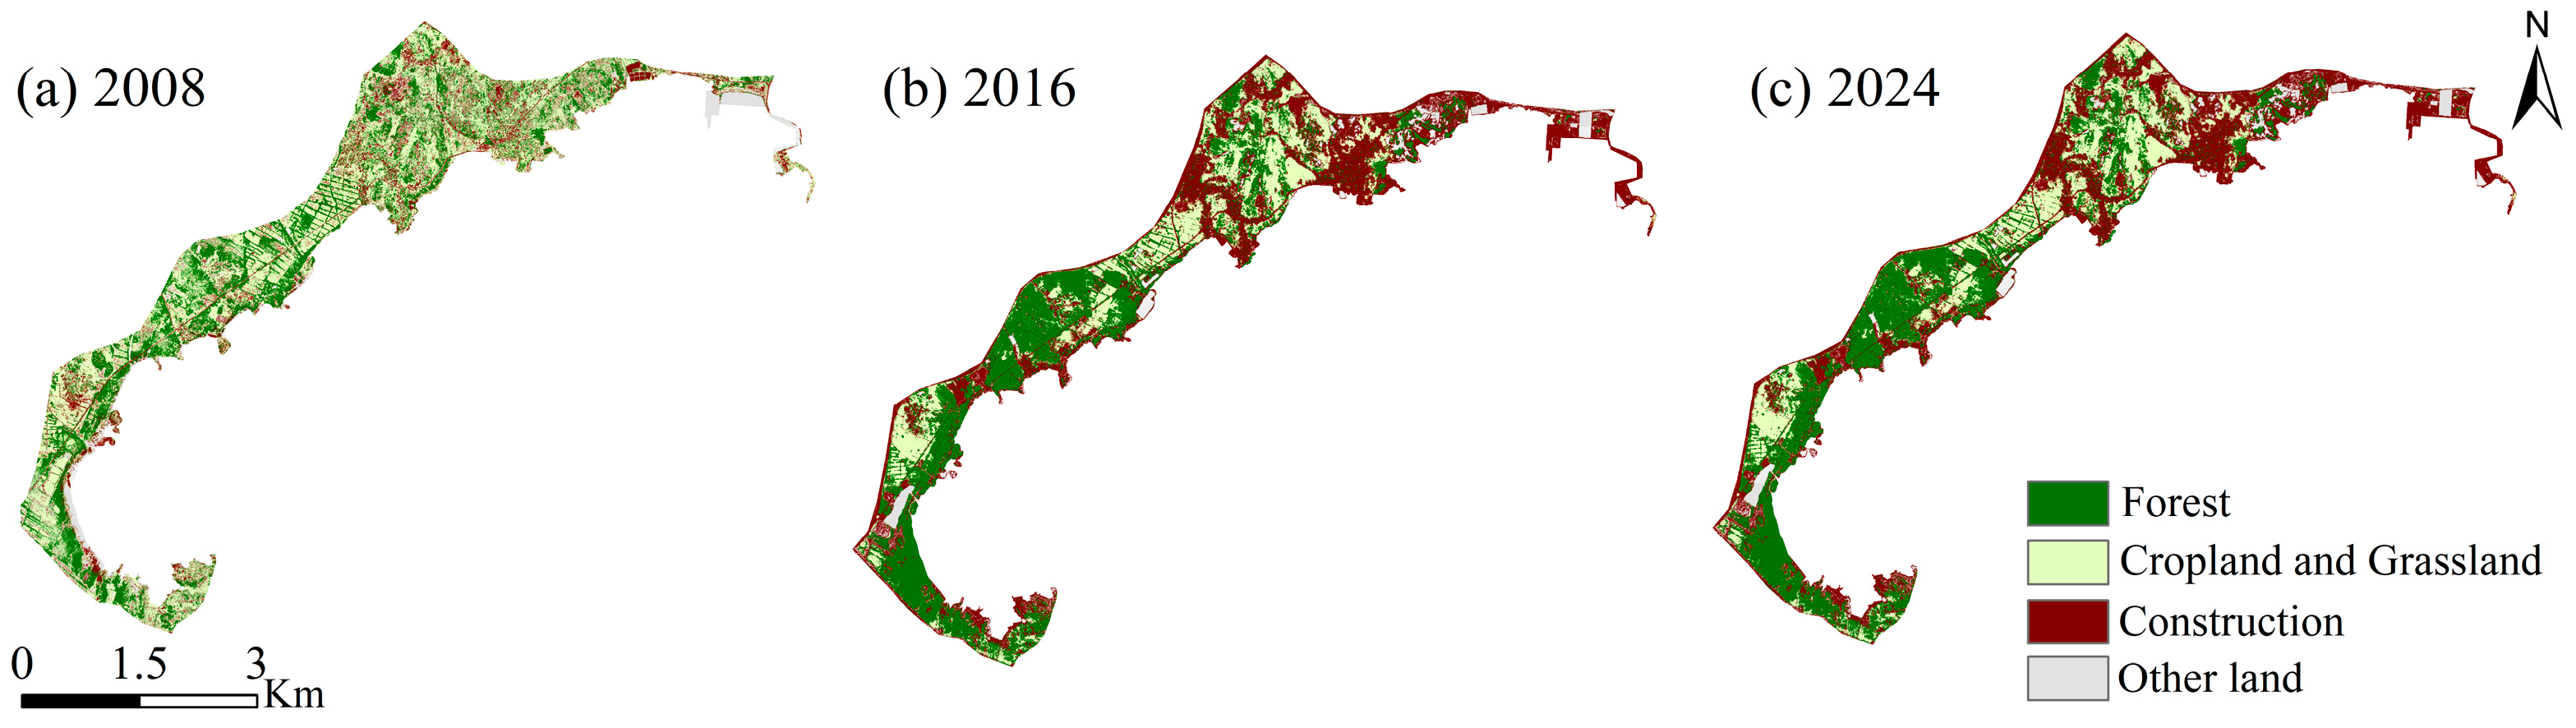
Using a support vector machine (SVM) in ArcGIS, land use was classified into Forest Land, Construction Land, Cropland and Grassland, Water, Beach, and Bare Land. The rationale for treating cropland and grassland as a single class is described below. Comparison with the land-use category maps from Pingtan’s Third National Land Survey showed that grassland patches in the study area are mostly small and spatially dispersed and are interspersed with cropland patches. For such fragmented and interspersed low-growing vegetation surfaces, crops and grassland can exhibit similar surface-cover characteristics and spectral responses at particular phenological stages, with limited spectral-band differences. Their remote-sensing identification is therefore susceptible to vegetation growth status and image acquisition timing, which limits fine-scale separation based on single-date imagery [
28,
29]. Meanwhile, the IGBP global land-cover classification includes a Cropland/Natural Vegetation Mosaic class to represent heterogeneous surface units formed by interspersed cropland and natural vegetation, indicating that composite or mosaic classes are an existing mapping approach in remote-sensing land-cover mapping where spatial mixing is pronounced [
30]. Given differences in acquisition season and sensor among the three image dates, cropland and grassland were combined into the single class Cropland and Grassland to reduce cross-period confusion between these fragmented and interspersed classes and to maintain class consistency in land-use change analysis and subsequent SD–PLUS simulation. This class was used to characterize the overall area, landscape pattern, and land-use transitions of cultivated surfaces and herbaceous vegetation cover in the study area.
Historical comparisons and scenario simulations in this study focused primarily on changes in area, spatial patterns, and interconversion among Forest Land, Cropland and Grassland, and Construction Land. Although Water, Beach, and Bare Land have distinct surface-cover characteristics, none were treated as an independent land-demand or major scenario-response class within the analytical framework. To maintain a consistent class system across landscape-pattern analysis, classification-accuracy assessment, and SD–PLUS simulation, the three classes were combined as Other Land. This aggregation was applied only in subsequent analyses; the original classification information was retained to identify the historical land-use transitions of Water, Beach, and Bare Land separately. Throughout this study, these terms are capitalized when they refer to the formally defined land-use classes. Cropland and Grassland is treated as a single land-use class in the classification and subsequent analyses.
For classification accuracy assessment, 200 validation points were generated for each bay in each year using stratified random sampling, with the number of points allocated among land-use classes in proportion to their relative areas. The reference land-use class at each validation point was visually interpreted using the reference imagery described above. After quality control, 168 and 179 valid validation points were retained for Tannan Bay and Haitan Bay, respectively, in 2008, while all 200 points were retained for each bay in 2016 and 2024. Overall accuracy (OA) and Kappa coefficients are summarized in
Table 2, while class-specific producer’s accuracy (PA), user’s accuracy (UA), and complete confusion matrices are provided in
Table S7.
2.3. Methods
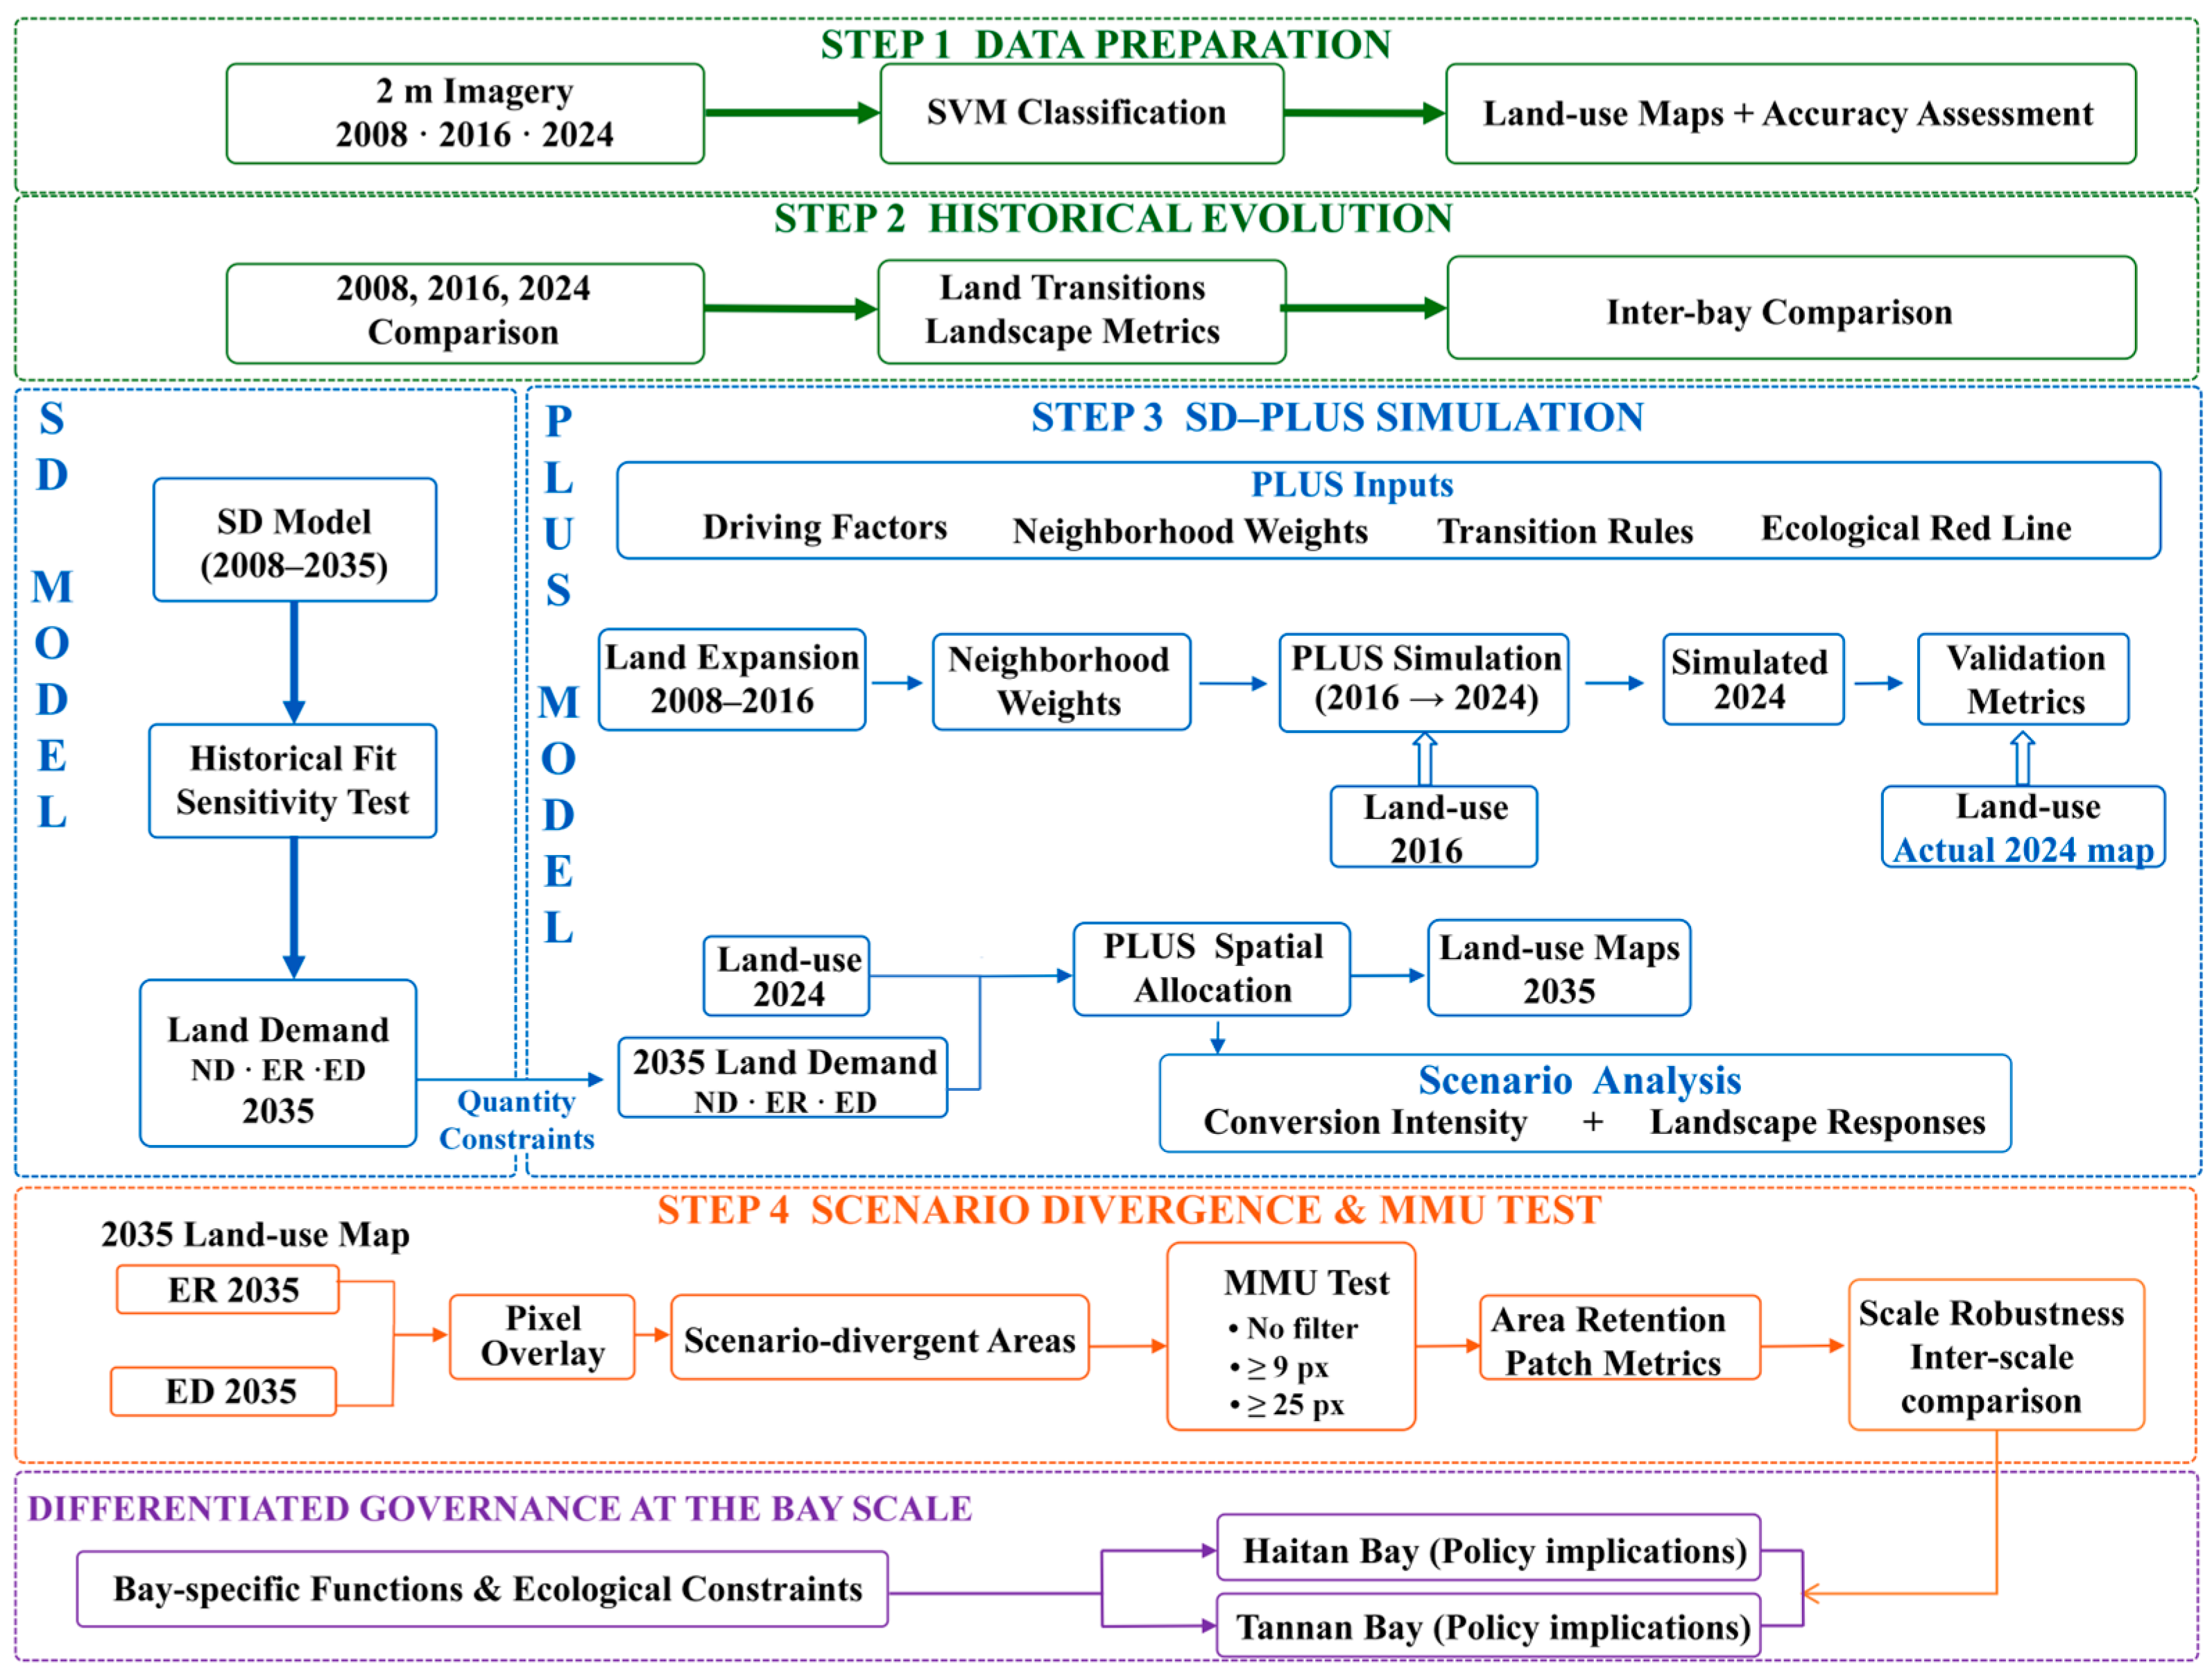
The analysis comprised three interlinked analytical levels. (1) Common study boundaries, land-use classes, and landscape metrics were used to compare major land-use change patterns and existing landscape characteristics in both bays from 2008 to 2024. This comparison established a consistent historical baseline for scenario analysis. (2) The SD model projected land demand under ND, ER, and ED. The PLUS model then allocated land use spatially in 2035 using driving factors, neighborhood weights, transition rules, and ecological constraints. (3) ER and ED in 2035 were overlaid pixel by pixel to identify areas where policy-oriented land-allocation differences were most concentrated. Different MMU settings were then used to test the scale robustness of the extent and patch structure of divergent areas. The overall analytical framework is shown in
Figure 2.
2.3.1. Historical Land-Use Evolution and Landscape Pattern Analysis
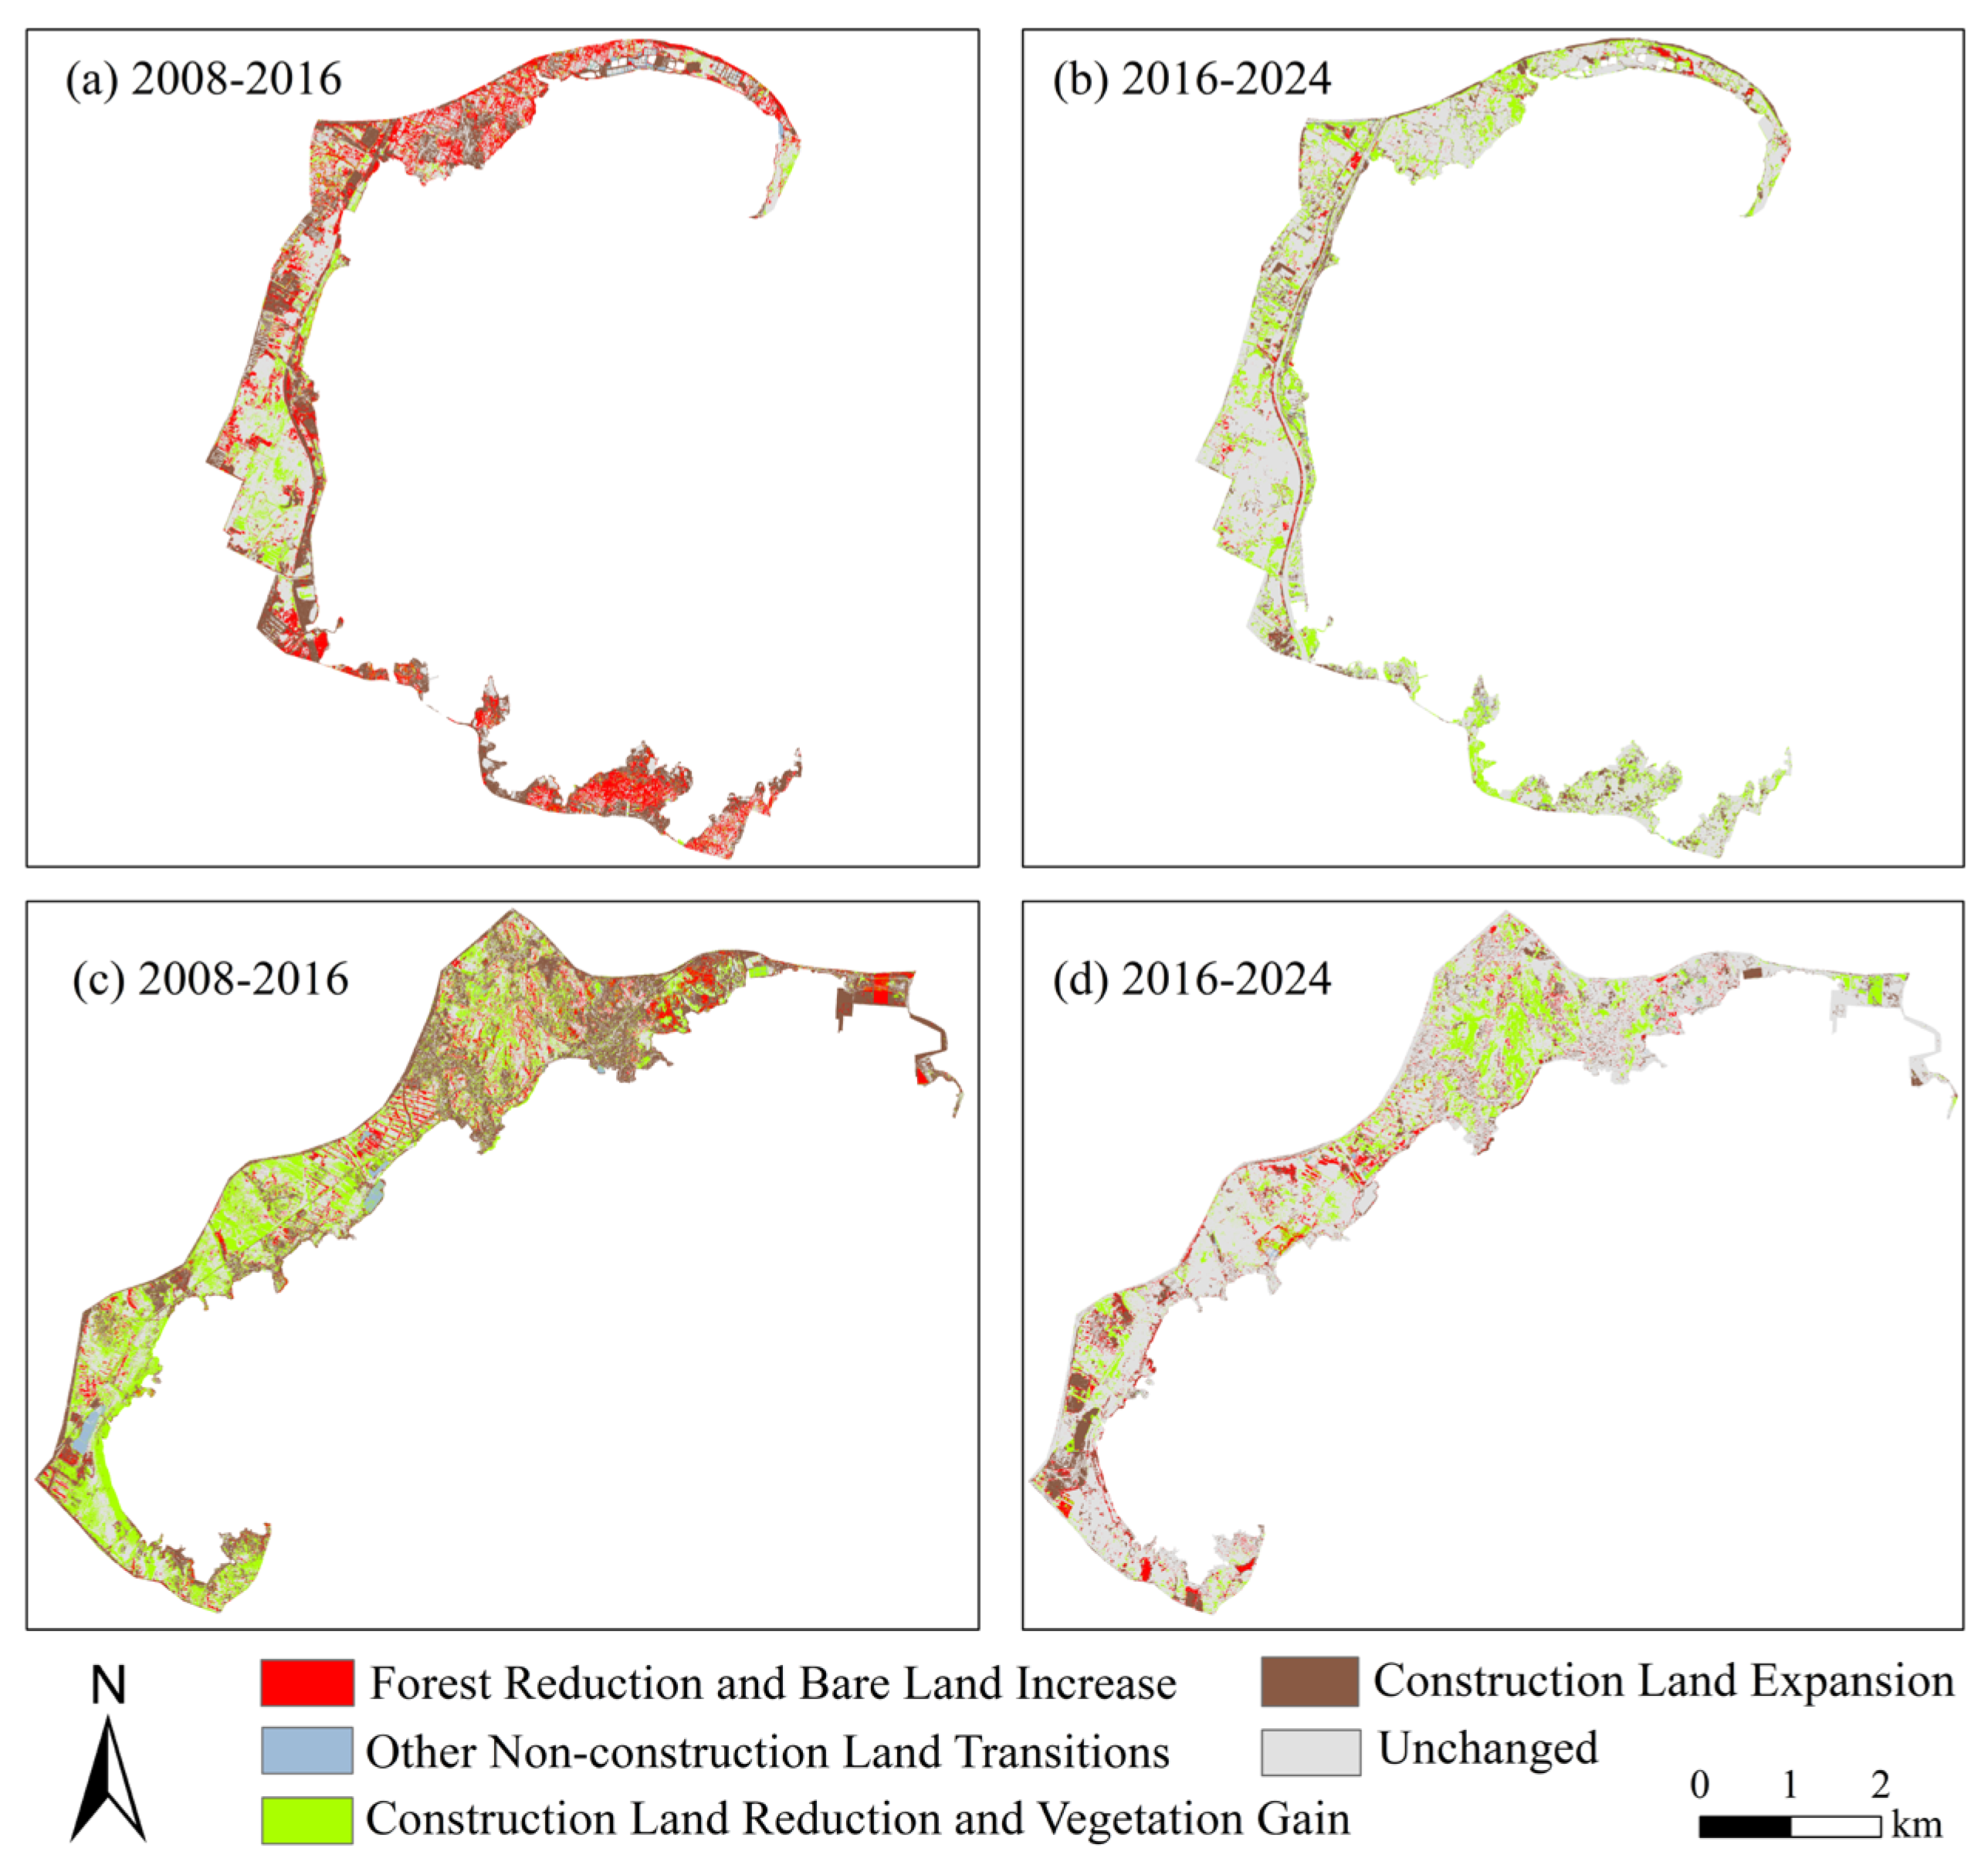
To characterize the spatial distribution of major land-use changes, representative land-use transitions were summarized into four thematic transition groups according to their initial and final land-use classes: Construction Land Expansion, Construction Land Reduction and Vegetation Gain, Other Non-construction Land Transitions, and Forest Reduction and Bare Land Increase. Pixels with the same initial and final land-use class were classified as Unchanged Area. These thematic groups were used primarily to simplify the spatial representation of major land-use transitions and to facilitate comparison of the major land-use change processes between the two bays. Arrows indicate directed transitions from the initial land-use class to the final land-use class, and reverse transitions were treated as distinct land-use change processes. The land-use combinations corresponding to each category are listed in
Table 3.
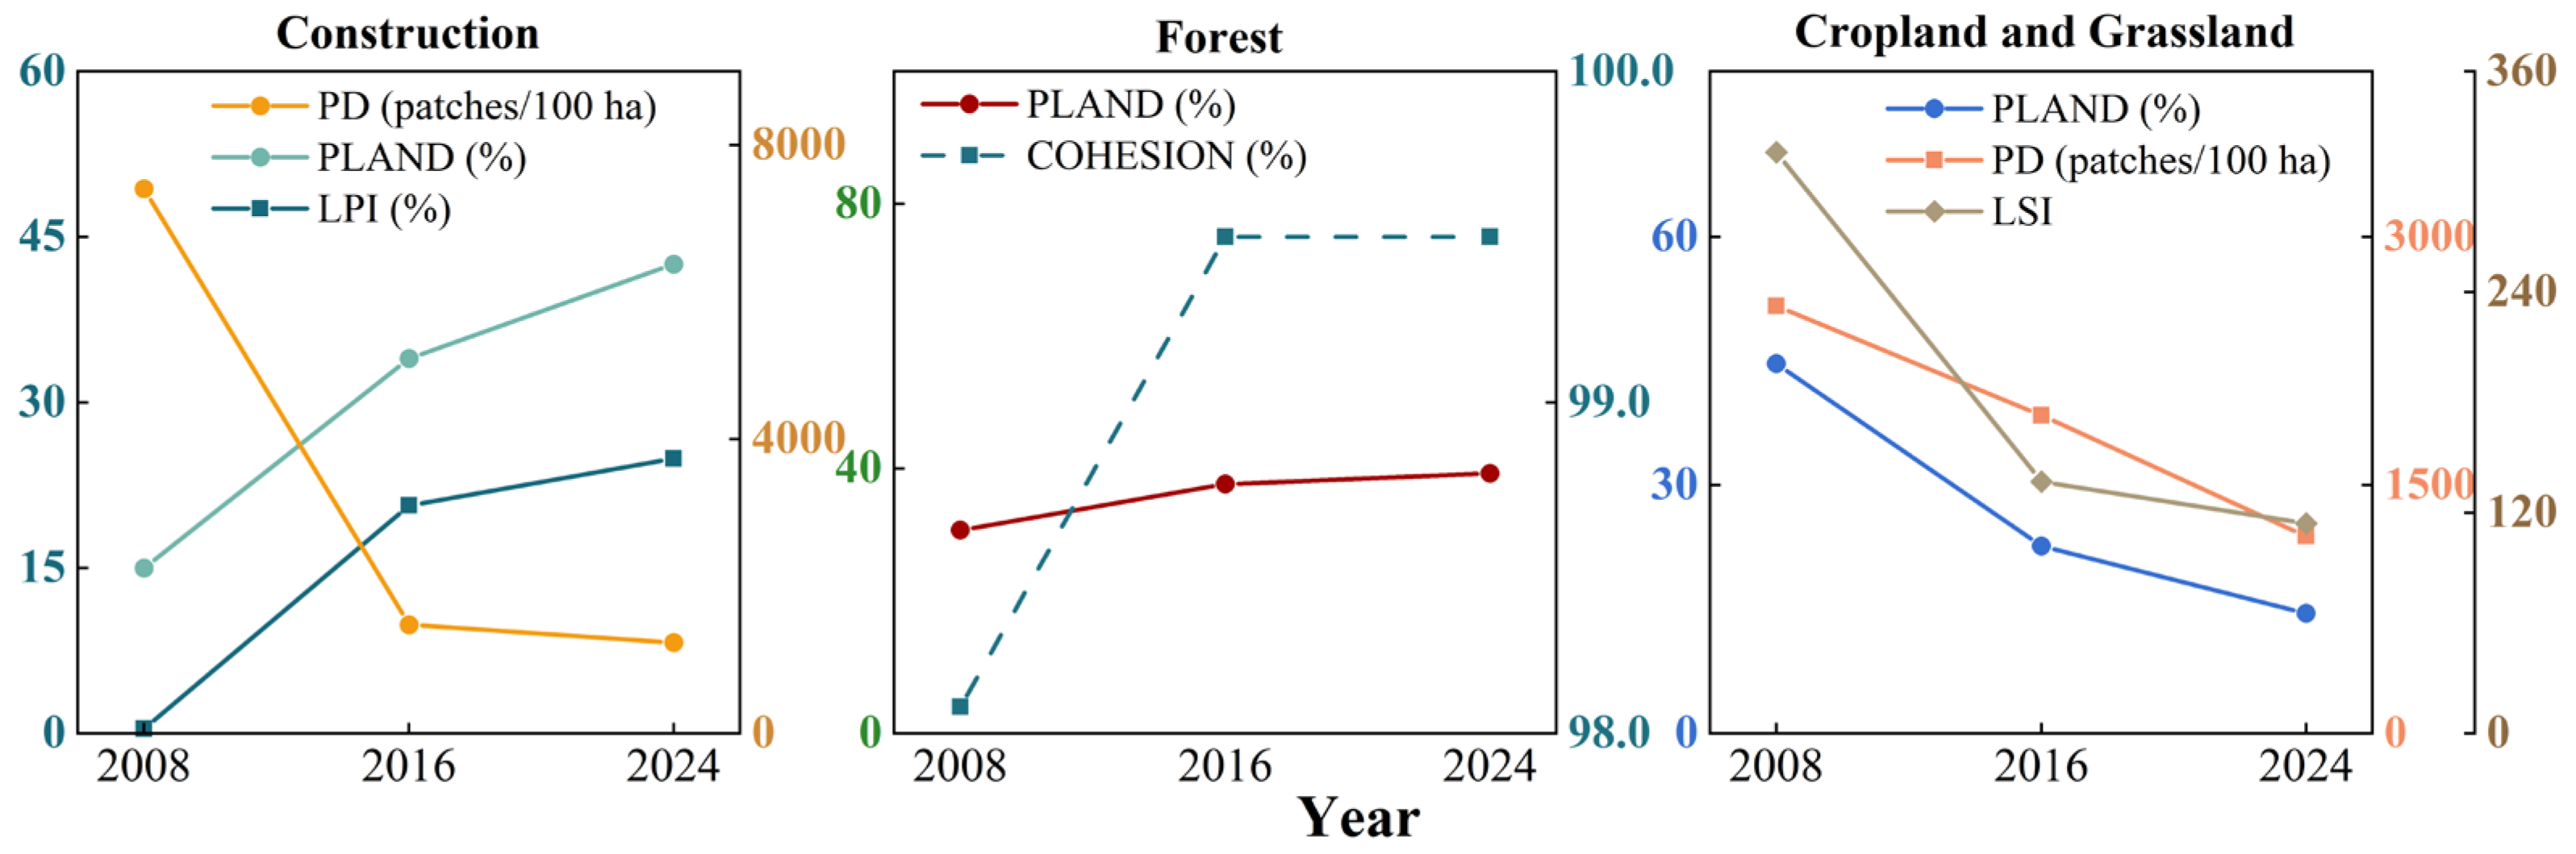
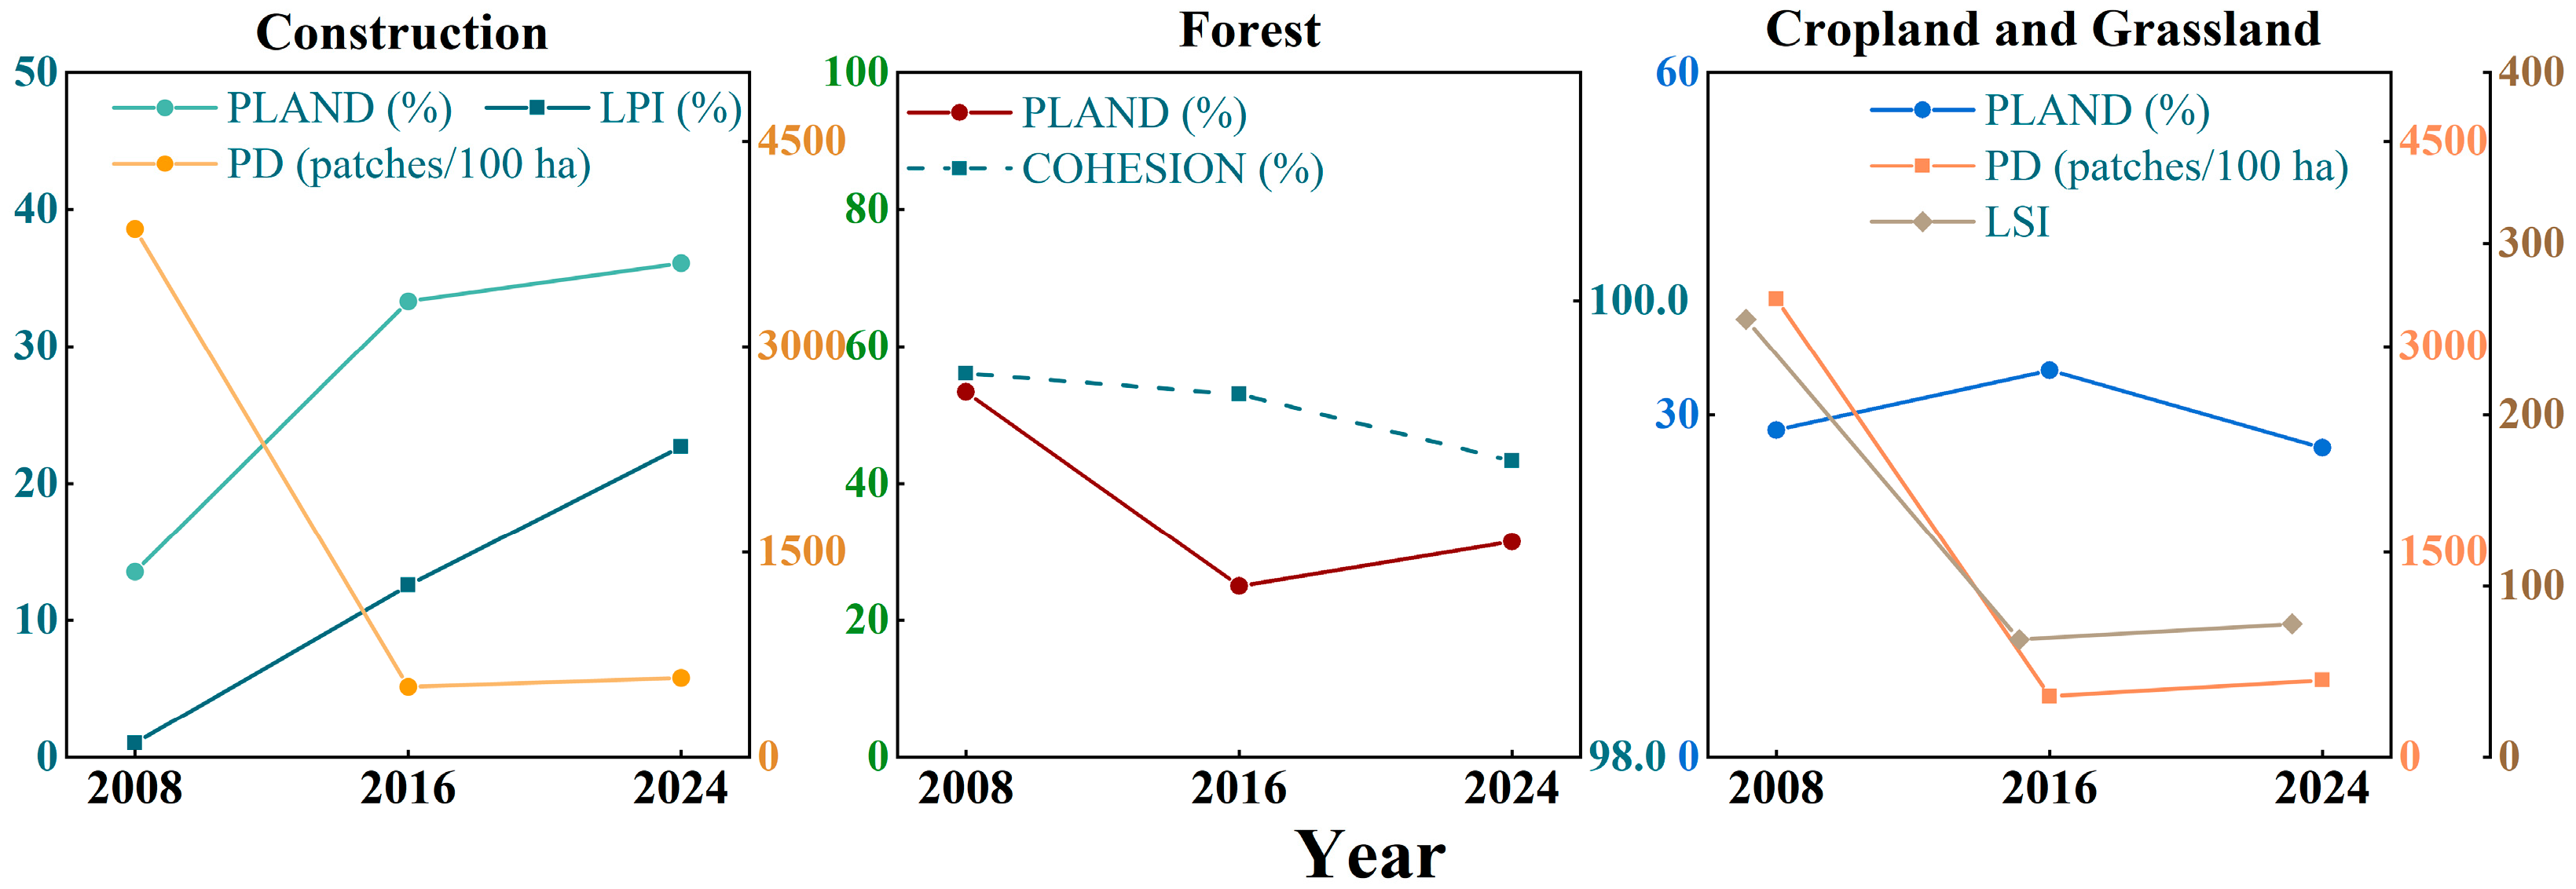
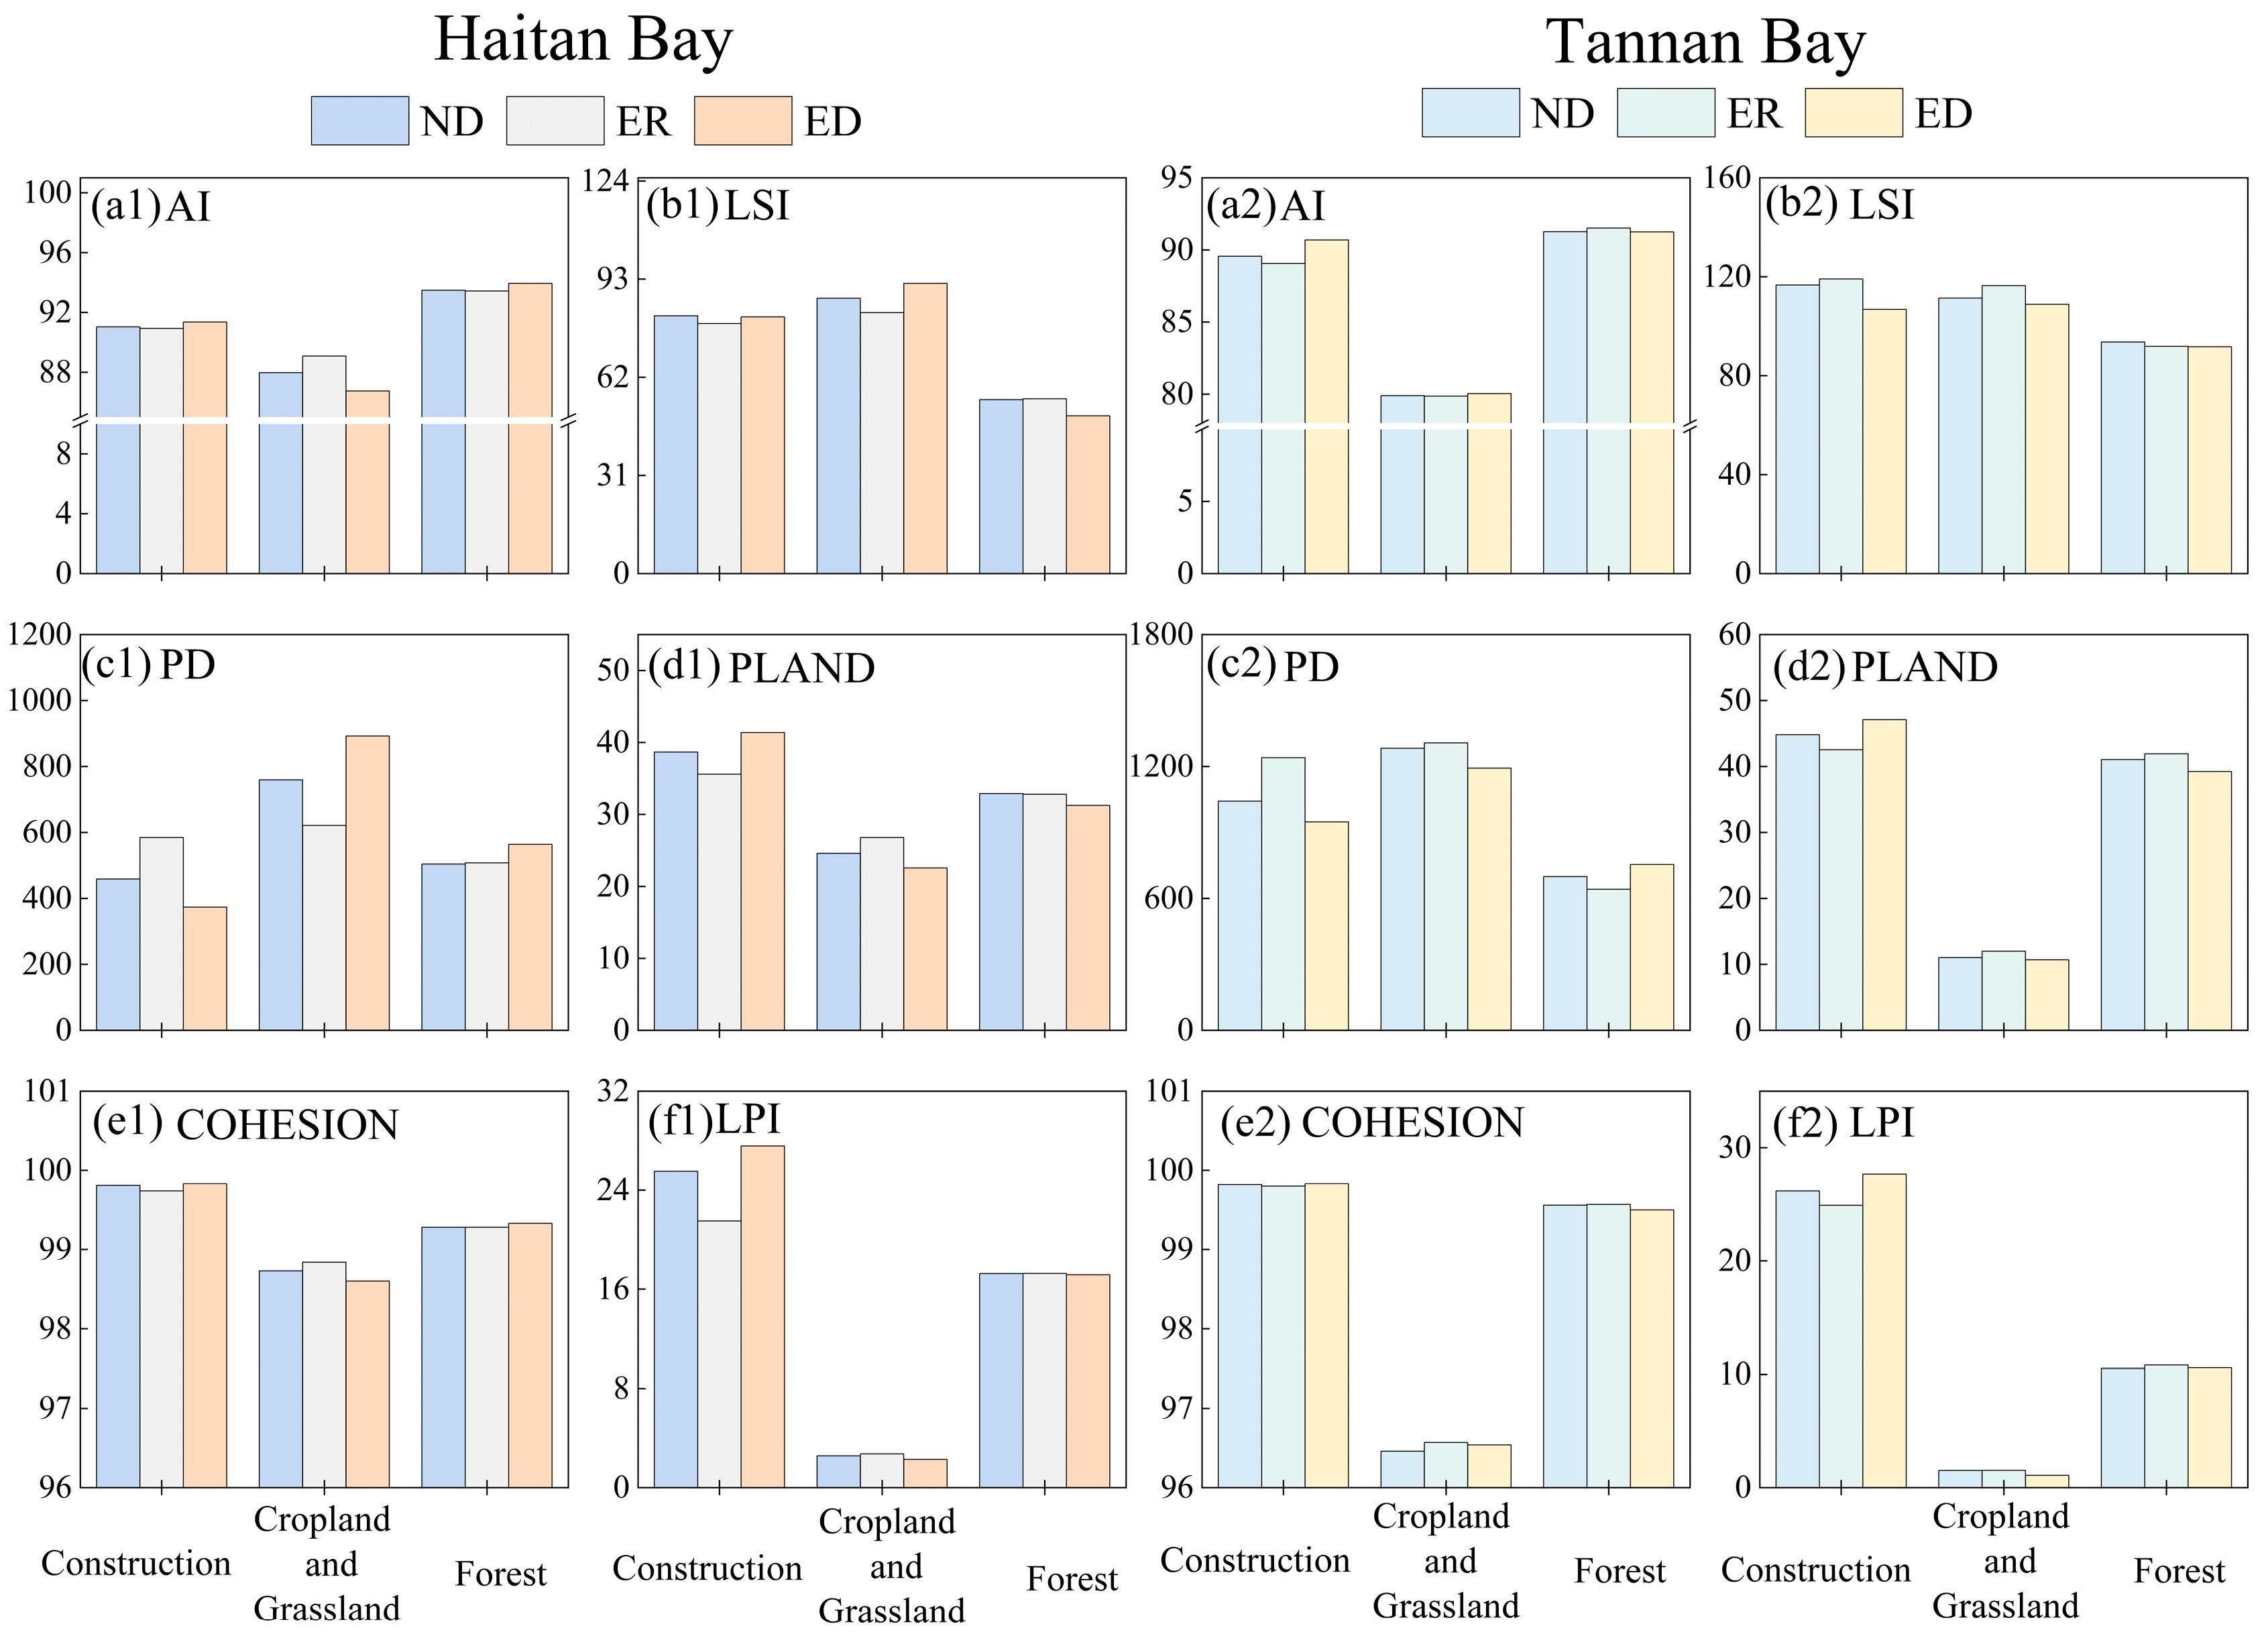
Six class-level landscape metrics—PLAND, PD, LPI, LSI, COHESION, and AI—were calculated using FRAGSTATS 4.2. The land-use rasters for both bays were clipped to their respective study-area boundaries, with pixels outside the study areas set to NoData and excluded from calculation. Patches were identified using the default 8-neighbor rule in FRAGSTATS, whereby pixels of the same land-use class sharing an edge or a corner were treated as belonging to the same contiguous patch, whereas areas separated by other land-use classes or NoData pixels were identified as separate patches. AI was calculated according to the FRAGSTATS definition of like adjacencies, in which pixel adjacency considers shared edges only and excludes diagonal adjacency. These metrics describe the area proportion, number of patches, dominant patch, shape complexity, physical connectivity, and aggregation of each land-use class, respectively; detailed definitions are provided in
Table 4.
2.3.2. SD Model Construction and Validation
System Dynamics (SD) simulates complex social–ecological systems through stock–flow structures and feedback loops. It has been widely applied to regional sustainable development and environmental management [
31,
32]. An SD model was constructed in Vensim with a temporal extent from 2008 to 2035 and a 1-year time step. Model equations were formulated mainly using lookup and selection functions. Initial stocks were derived from the interpreted 2008 land-use data. Time series for socioeconomic drivers and related historical parameters were constructed and calibrated using statistical yearbooks and bulletins. Interpreted land-use areas for 2016 and 2024 served as historical observations for evaluating the model’s reproduction of past changes in land quantity. The ecological carrying capacity threshold, Maximum Construction Land Capacity, and land-use conversion regulation parameters were determined from planning documents, historical ranges, and previous studies. Parameter sources and calibration procedures are summarized in
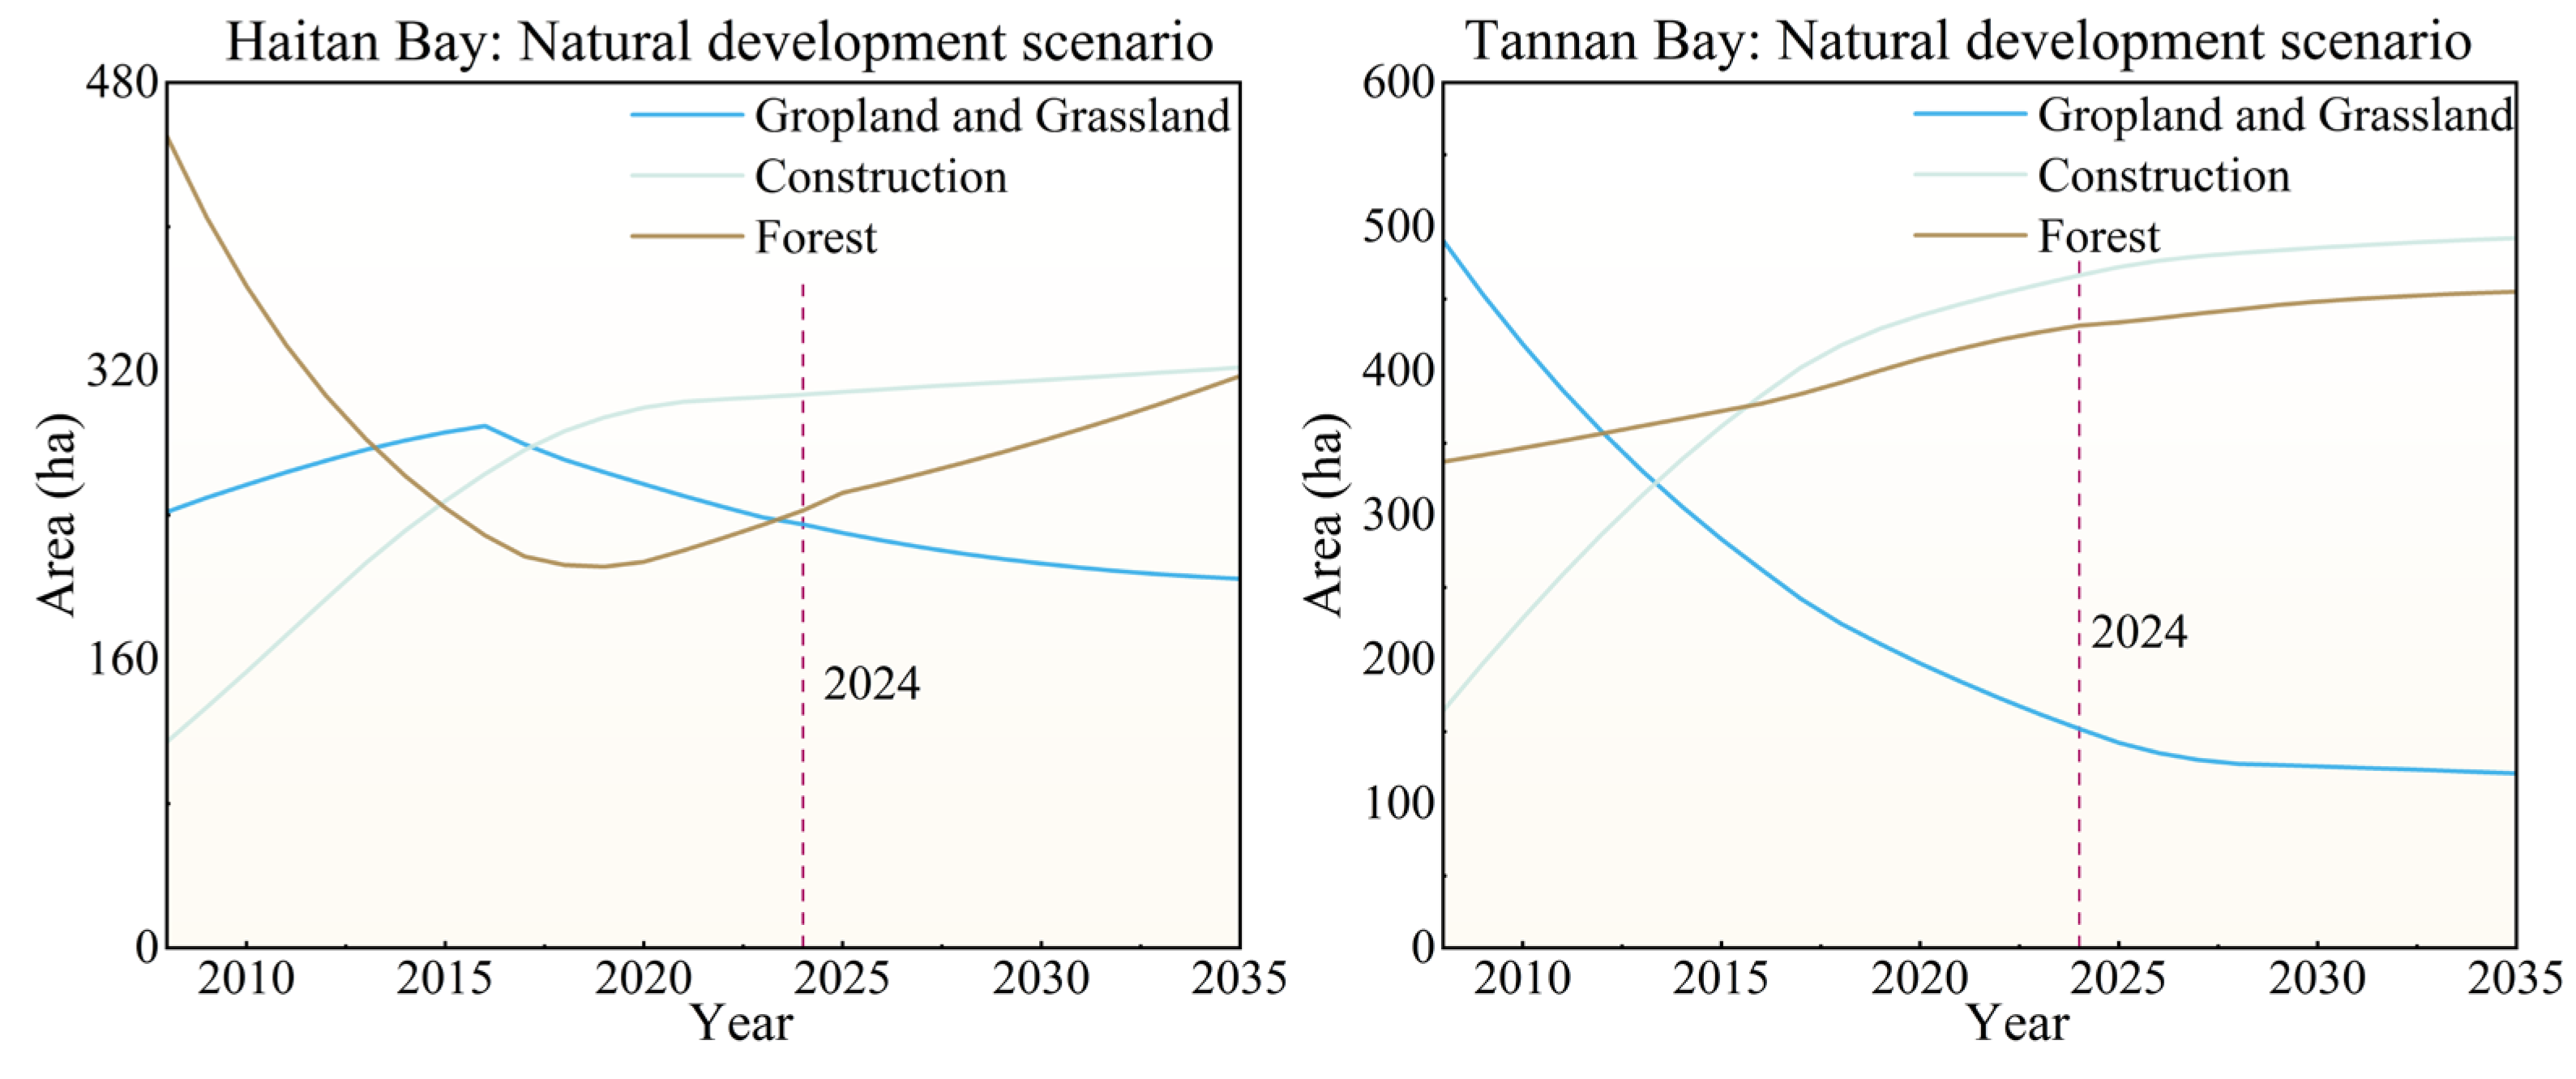
Table S6. All future scenarios began from the 2024 land-use state and were simulated to 2035. Because the two bays differ substantially in ecological background and functional role, they shared the same core stock–flow framework but used differentiated flow functions and parameters.
Forest Land provides important carbon-storage and ecological-regulation functions, and changes in its pattern are closely related to forest ecosystem resilience [
33,
34]. Cropland and Grassland is an important open, non-construction land-use class in the study area. Changes in its area and spatial pattern can reflect the overall adjustment of cultivated surfaces and herbaceous vegetation cover during land development and vegetation restoration [
35]. Construction Land concentrates population, industry, and infrastructure activities [
36]. Bare Land provides relatively limited integrated land-use functions and ecosystem services [
37].
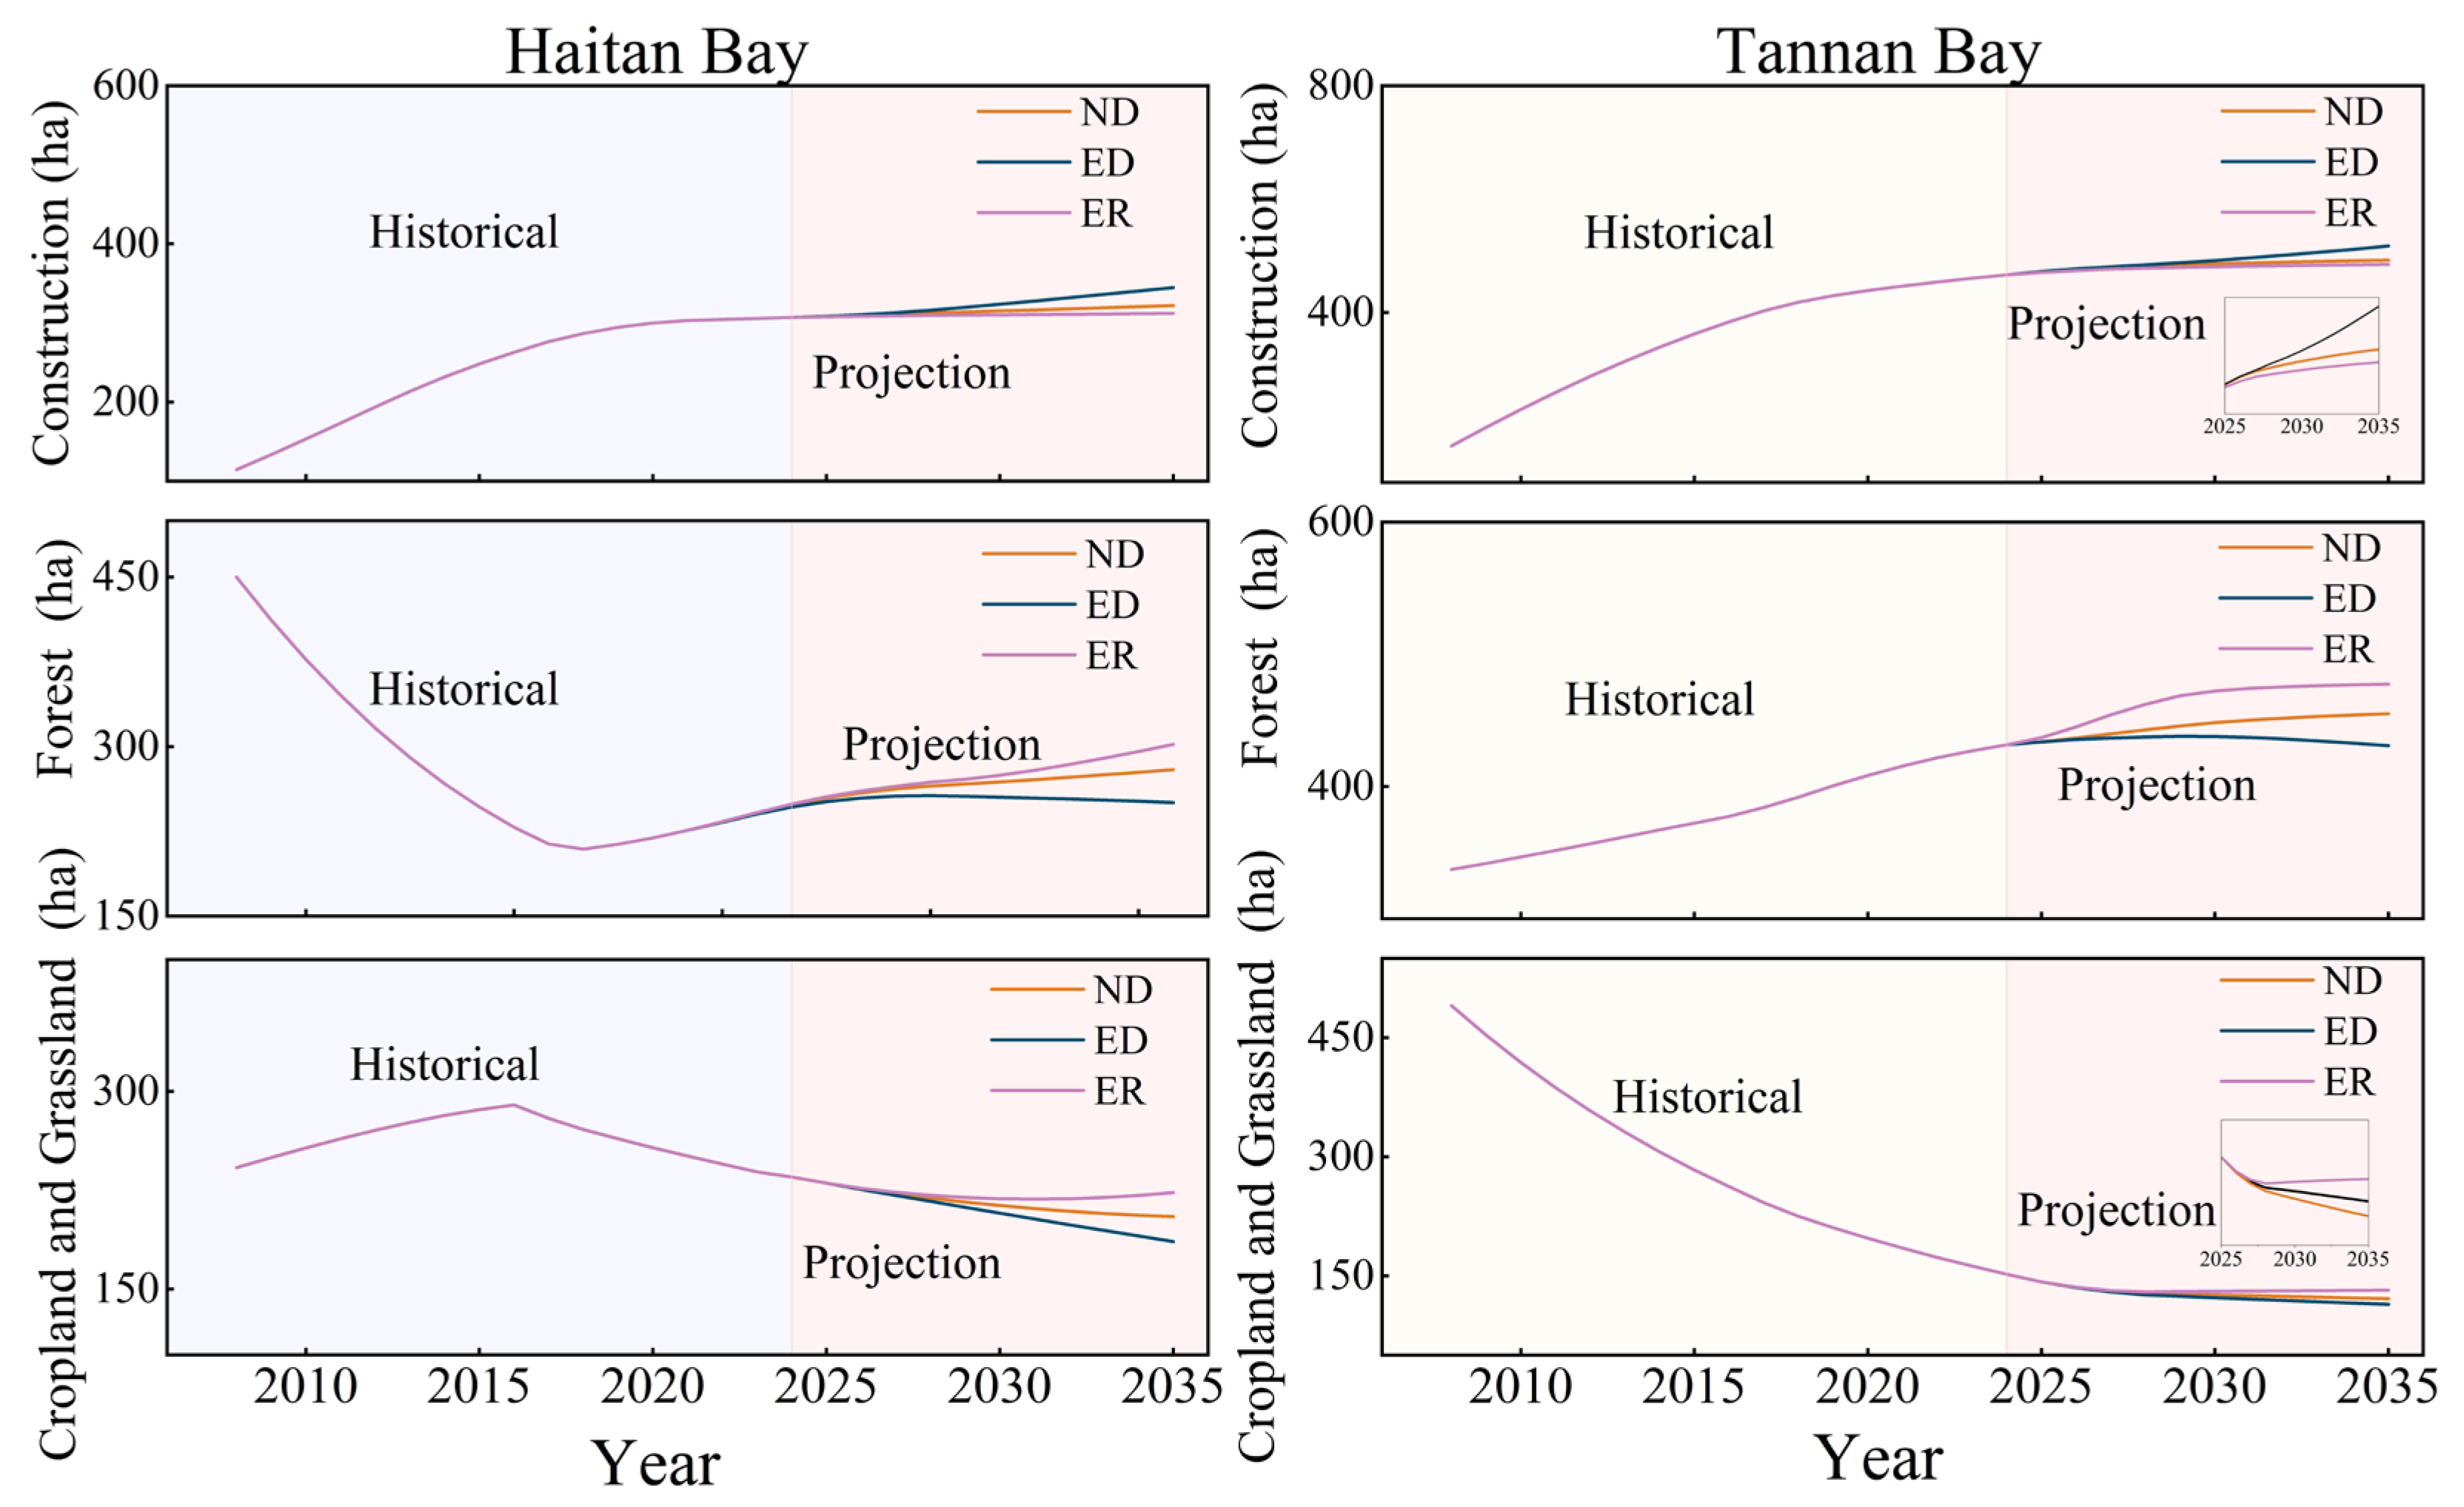
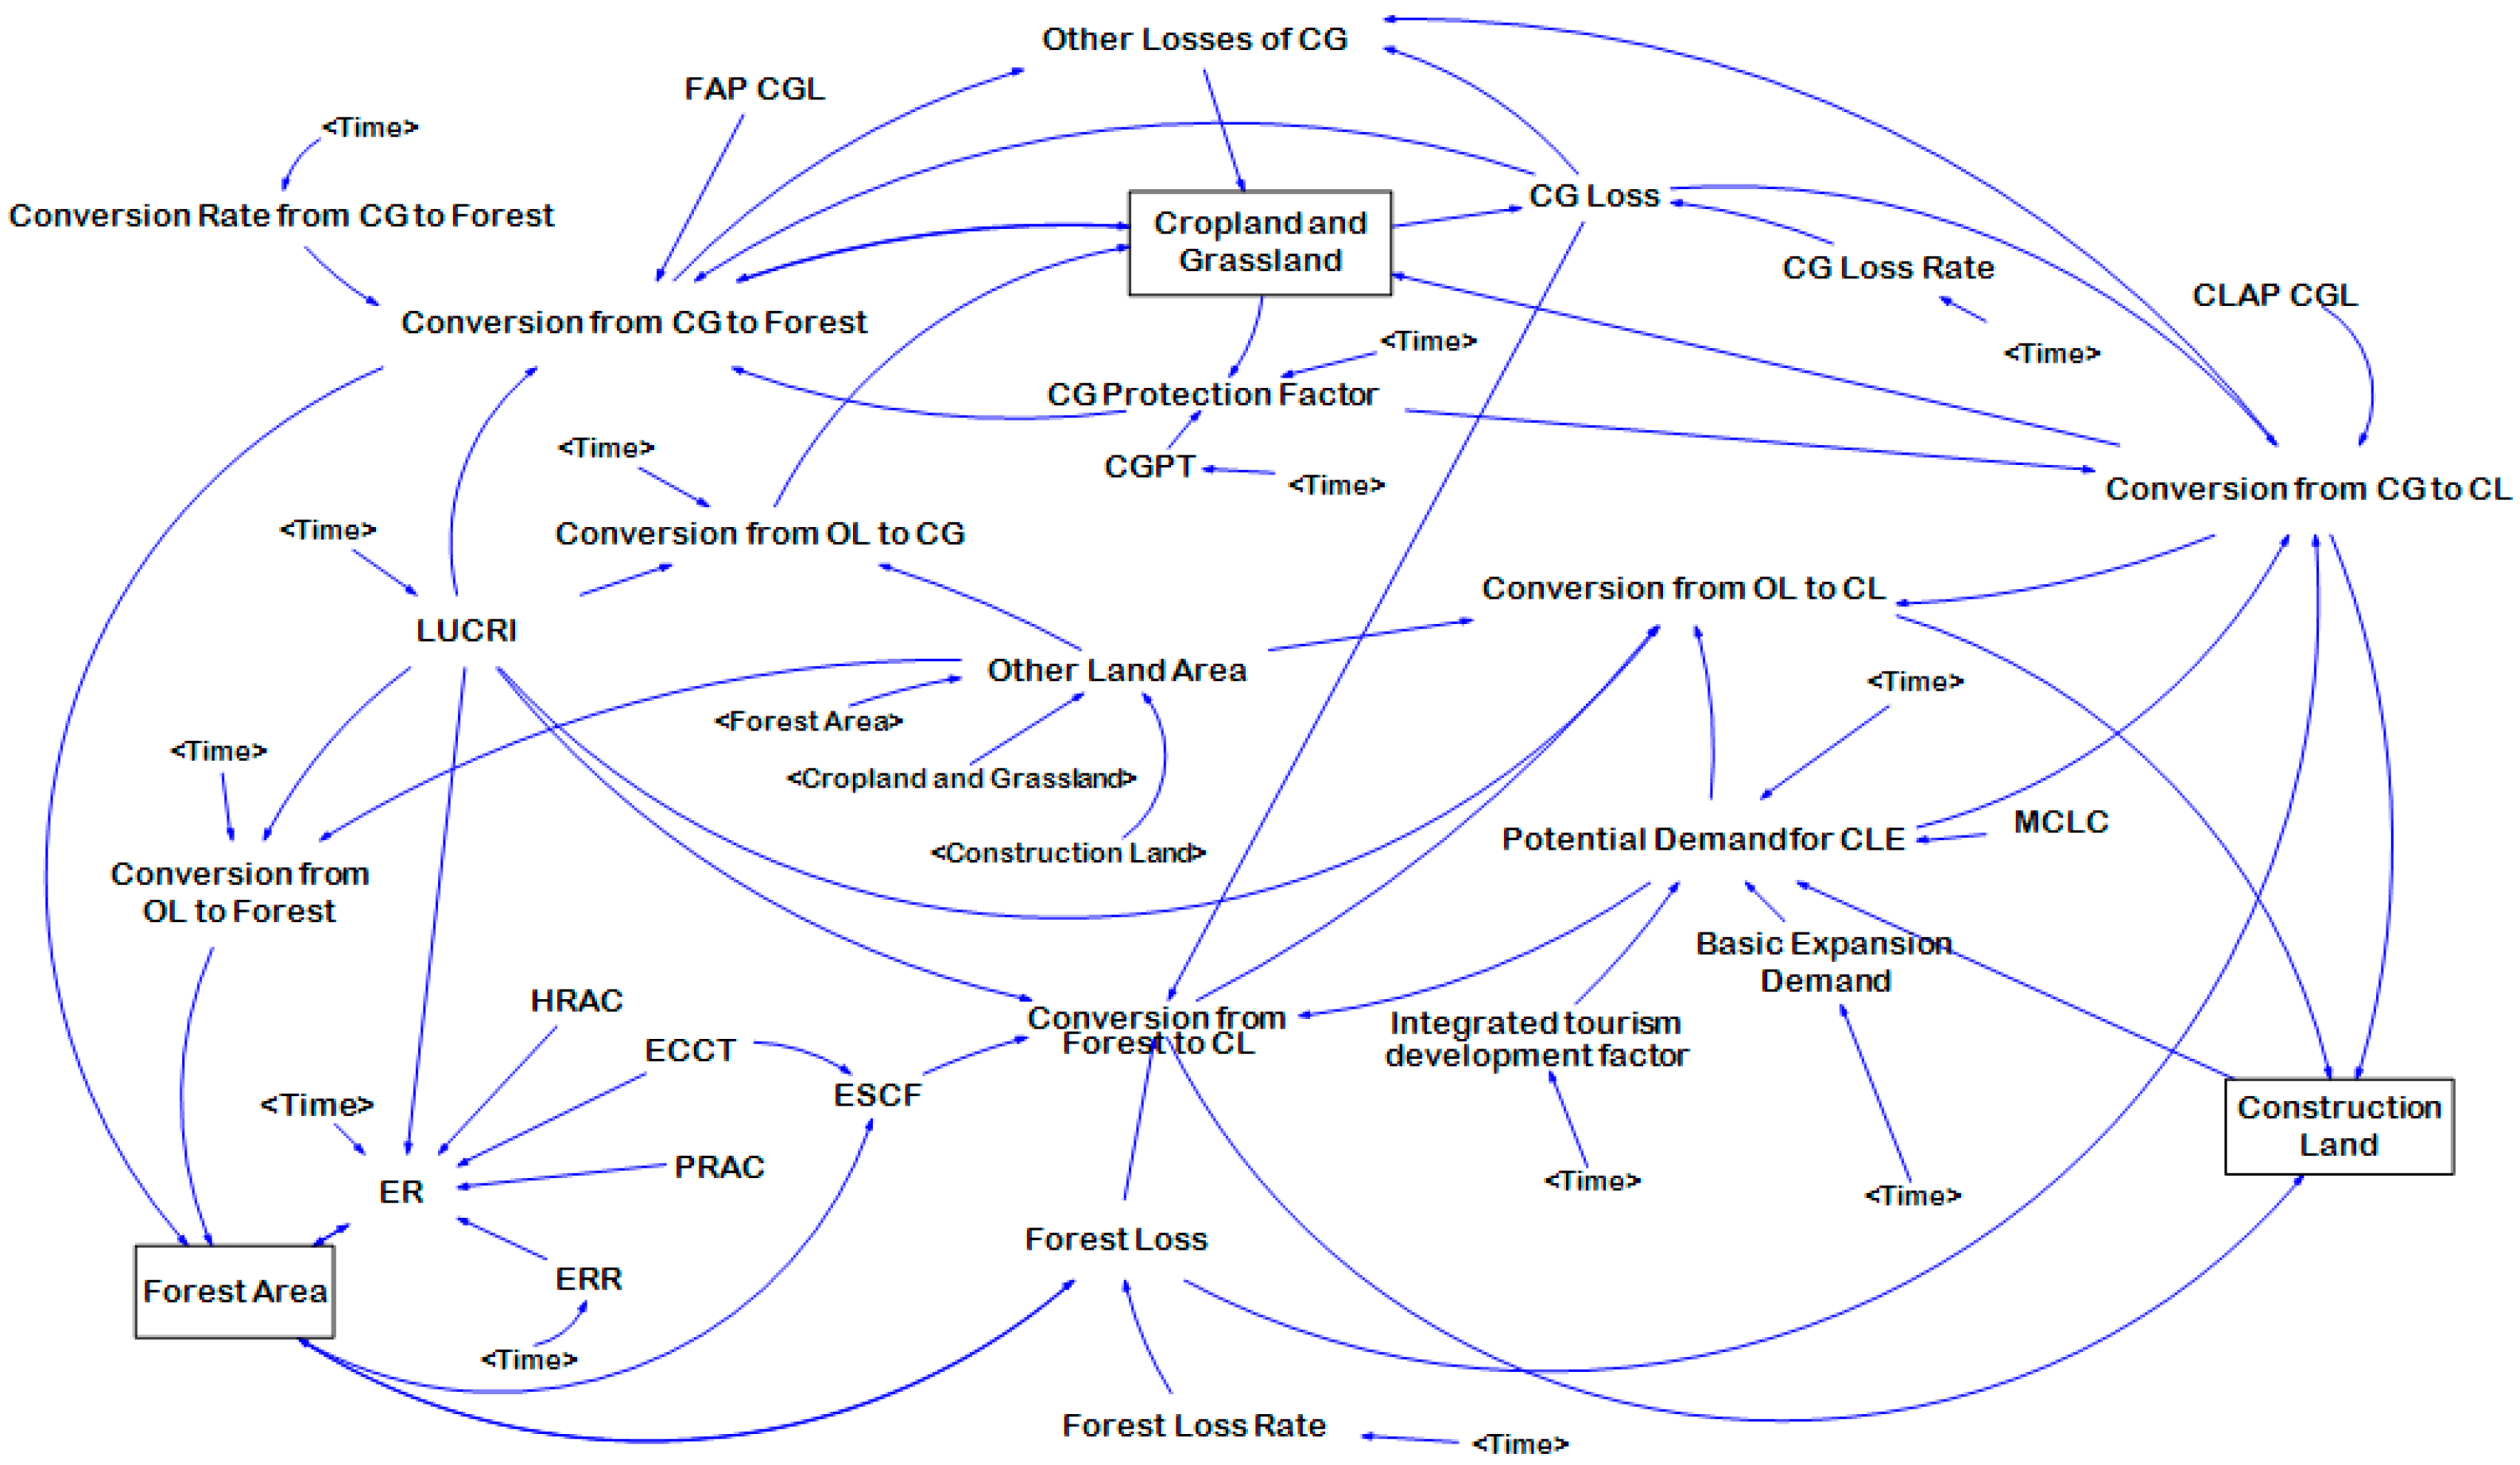
Construction Land Area (CLA), Forest Area (FA), and Cropland and Grassland Area (CGA) were defined as the core stocks. Potential demand for construction land expansion was determined jointly by Basic Expansion Demand (BED), Integrated Tourism Development Factor (ITDF), and Maximum Construction Land Capacity (MCLC). Within the SD–PLUS coupling framework, the influence of tourism development is represented mainly through ITDF in the SD land-demand component, which captures its effect on the demand for Construction Land. Conversion of Forest Land to Construction Land was constrained by both the Ecological Space Constraint Factor (ESCF) and Land Use Conversion Regulation Intensity (LUCRI). ESCF represents the constraint imposed by Forest Area relative to the Ecological Carrying Capacity Threshold. Other Land, comprising Water, Beach, and Bare Land, was treated as an area-balancing term and a source of conversion. The model structure is shown in
Figure 3, and variable definitions, units, and complete equations are provided in
Table S1.
Model validation for the SD simulation comprised a historical fit test and sensitivity analysis. The historical fit test assessed model reliability by comparing simulated results with observed historical data and evaluating the degree of fit. Relative error was calculated using Equation (1):
where
Si,t and
Hi,t are the simulated and historically interpreted areas, respectively, for land-use class
i in year
t. Here,
i represents CLA, FA, or CGA, and
t represents 2016 or 2024. Areas are expressed in km
2, and the relative error was calculated separately for each land-use class in Haitan Bay and Tannan Bay.
Sensitivity analysis evaluated model robustness by varying key parameters and examining how changes in these inputs altered the forecasts. The sensitivity coefficient was calculated using Equation (2):
In Equation (2), SCx,y(t) is the sensitivity coefficient of variable Y with respect to parameter X at time t. ΔX and ΔY denote the changes in parameter X and output variable Y caused by the parameter perturbation, respectively. When SCx,y(t) < 1, the parameter is considered insensitive, indicating that the model remains relatively robust to variation in that input.
2.3.3. Multi-Scenario Settings
Policy choices inherently involve trade-offs among economic development, ecological conservation, and social benefits [
38]. Multi-scenario land-use simulation has been widely used to evaluate the ecological effects of alternative development strategies in coastal cities [
39]. This study established the Natural Development Scenario (ND), Economic Development Scenario (ED), and Ecological Restoration Scenario (ER). ND extended historical trends and existing regulation intensity and served as the baseline. ED increased BED and ITDF and raised the loss rates of Forest Land and Cropland and Grassland to represent stronger development demand. ER reduced construction demand and strengthened ecological protection through lower land-loss rates and higher Ecological Restoration Rate (ERR) or Planning-period Restoration Area Cap (PRAC), depending on the bay. Both bays followed the same scenario logic, but parameter values reflected their respective historical ranges, construction capacity, ecological background, and planning constraints. For the post-2024 simulations, the parameter settings in
Table S1 correspond to the ND baseline, while scenario-specific adjustments under ED and ER are provided in
Table S2.
2.3.4. PLUS Spatial Simulation and Validation
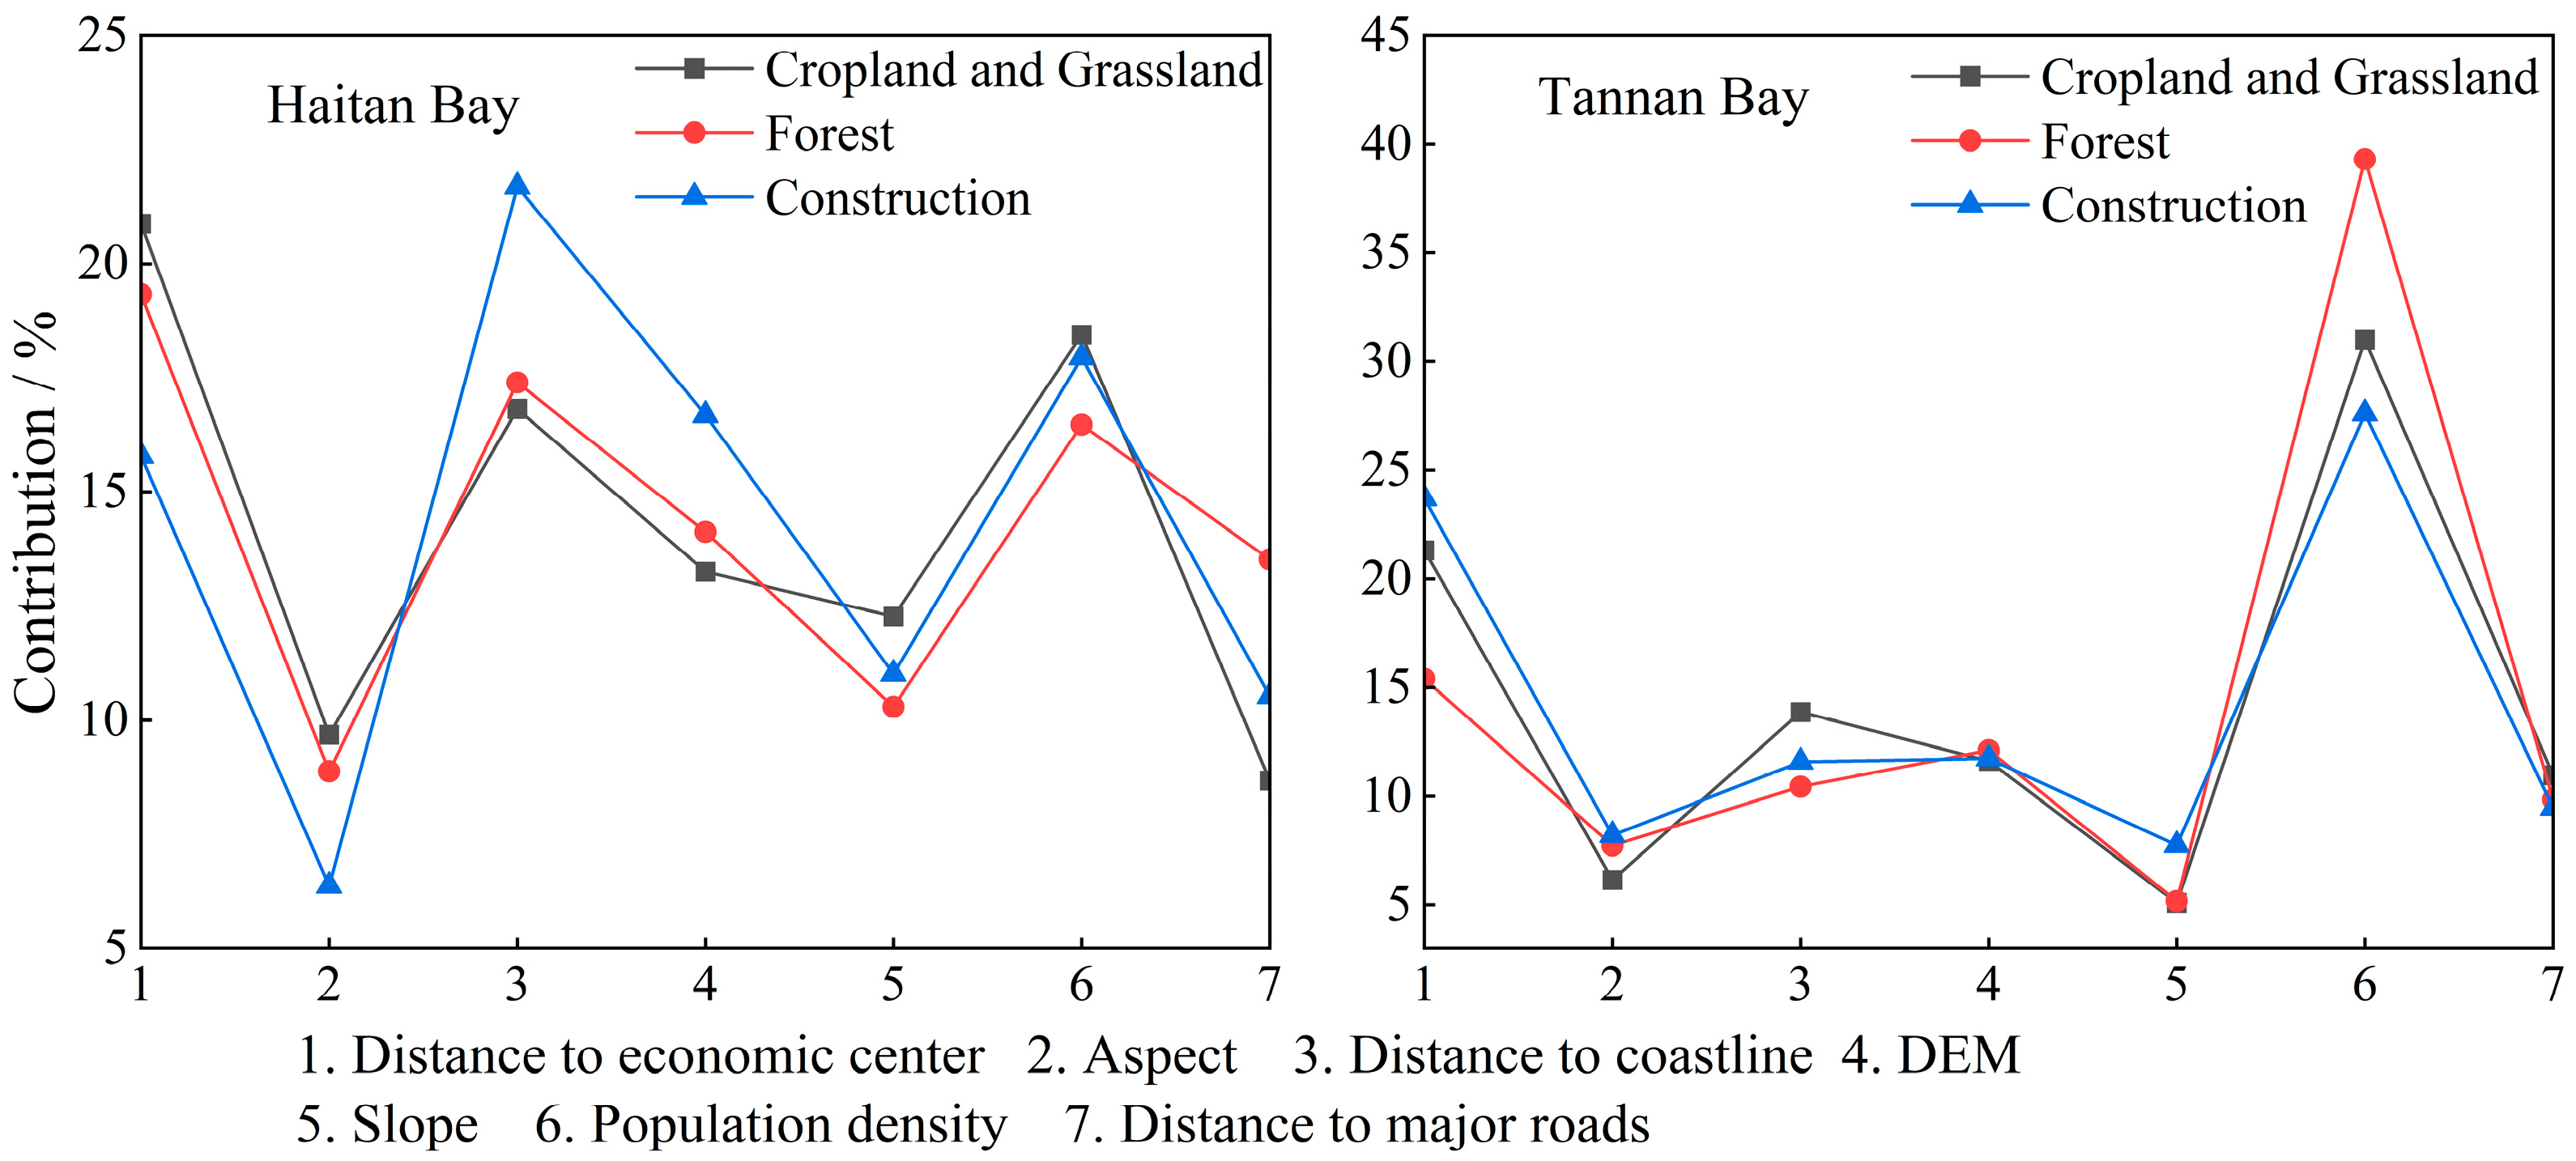
The Patch-generating Land Use Simulation (PLUS) model comprises the Land Expansion Analysis Strategy (LEAS) and CA based on multi-type random patch seeds (CARS). LEAS extracts expansion pixels for each land-use class from changes between two periods. It then uses a random forest to estimate the relative contributions of driving factors and growth probability. CARS generates future land-use patches by combining land demand, growth probability, neighborhood effects, transition rules, and spatial constraints. In the LEAS random-forest training, the number of regression trees was set to 20 and the sampling rate was set to 0.01. CARS simulations used a 3 × 3 neighborhood, with the patch-generation parameter set to 0.2, the expansion coefficient to 0.5, and the percentage of seeds to 0.005. Neighborhood weights, the land-use conversion cost matrix, and scenario-specific land-use demands were specified accordingly.
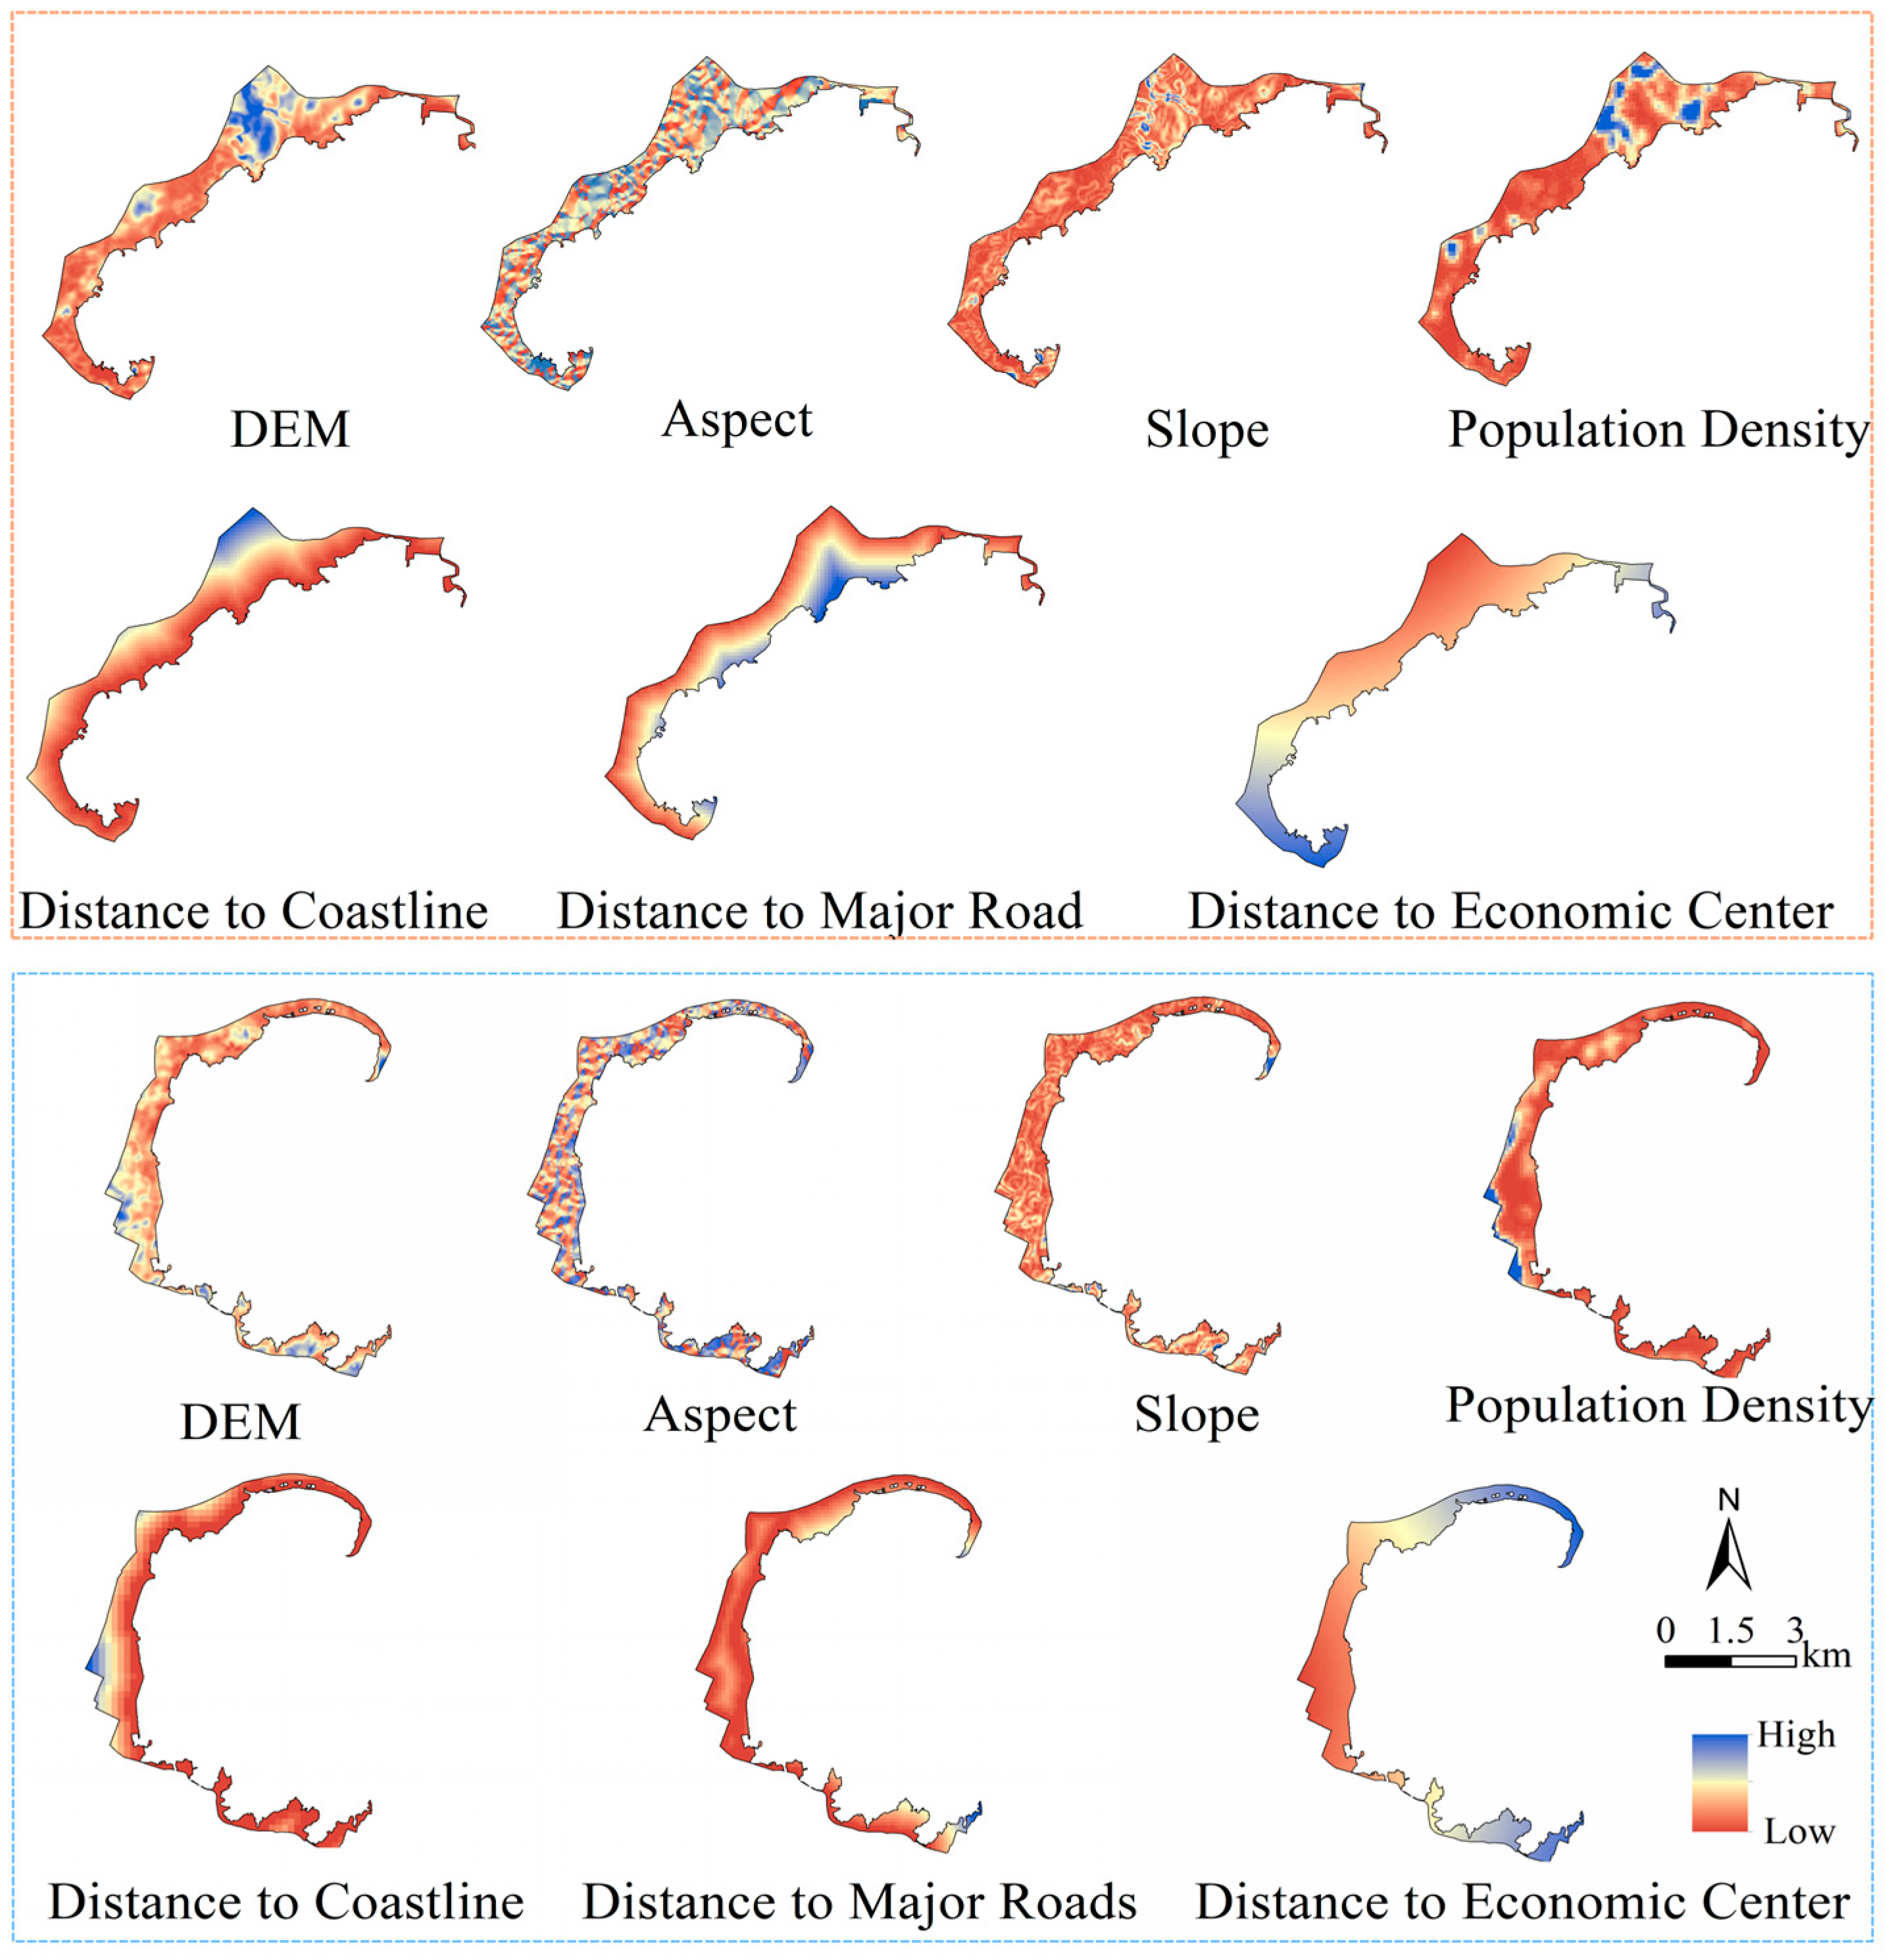
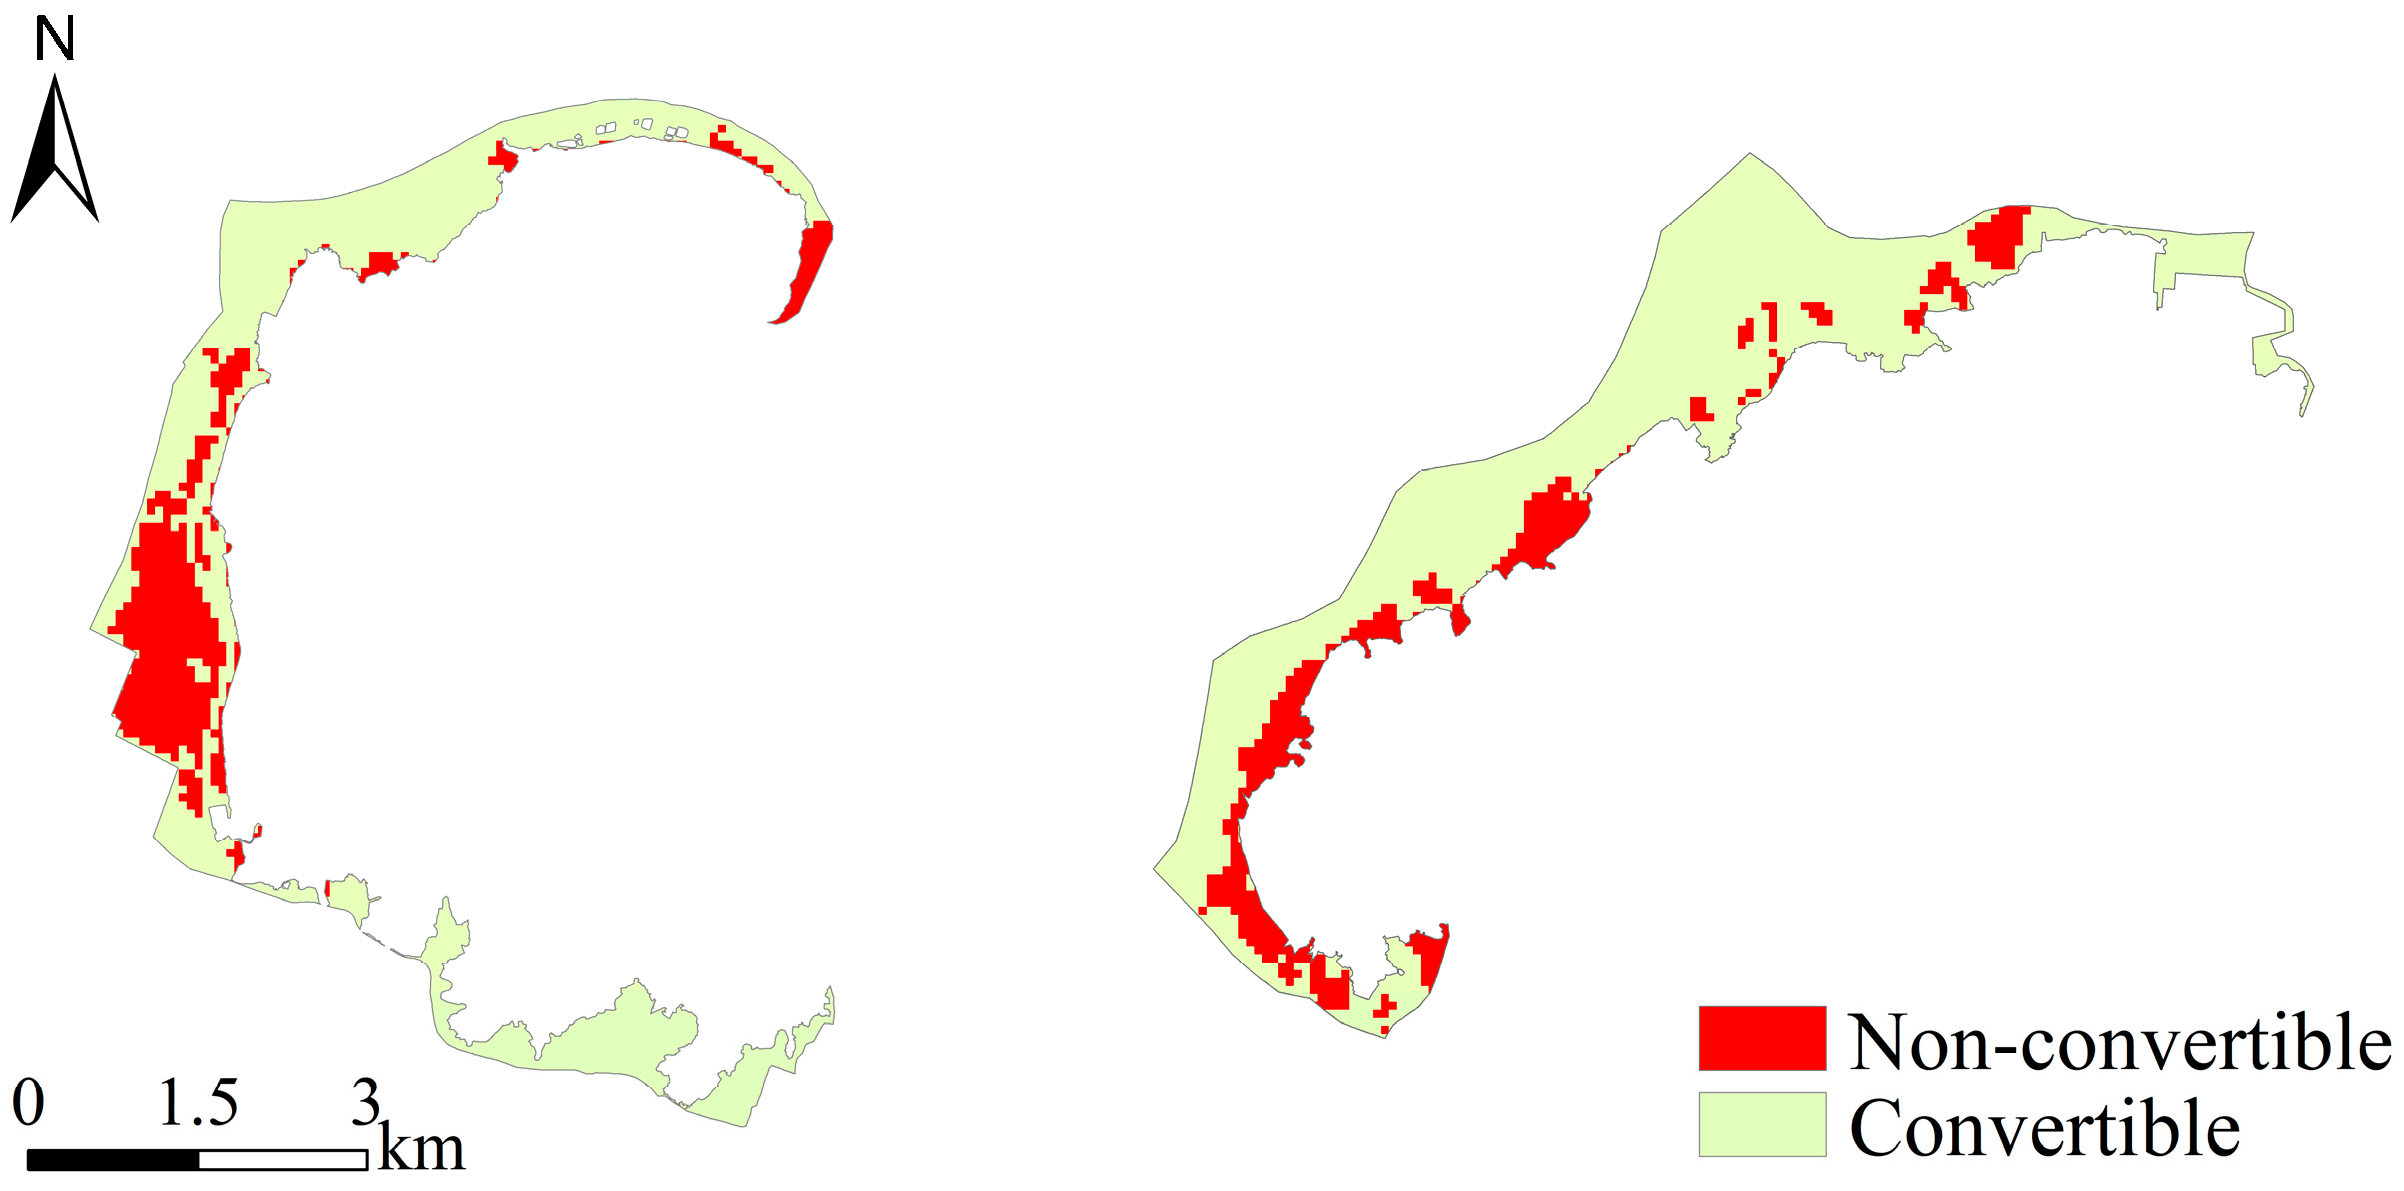
Seven driving factors were selected according to geographical characteristics and data availability. They were Population Density, Digital Elevation Model (DEM), Slope, Aspect, Distance to Major Roads, Distance to Economic Centers, and Distance to Coastline. All factors were standardized to the same projection, spatial resolution, and study extent. Distance variables were calculated using Euclidean distance. The ecological conservation redline was included as a restricted development zone in the spatial allocation. As a spatial constraint, the ecological conservation redline restricts where land-use conversions can occur in the scenario simulations and operates independently of the land-use conversion cost matrix. Values of 0/1 in the conversion cost matrix indicate only whether conversion between specific land-use classes is permitted under a given scenario, whereas the ecological conservation redline defines the spatial extent within which these conversions may occur. The driving factors and spatial constraints are shown in
Figure 4 and
Figure 5, respectively.
The period 2008–2016 was used to parameterize the neighborhood weights (
Table 5), followed by temporal validation for 2016–2024. Using the actual 2016 land-use pattern as the initial state, the neighborhood weights derived from 2008–2016 were applied to simulate the 2024 spatial pattern, which was then compared with the actual 2024 land-use map. During this temporal validation, the parameterized PLUS settings were not recalibrated. This process provided historical validation support for the subsequent 2035 scenario simulations.
For the 2035 spatial simulations, scenario-specific land demands generated by the SD model were used as the quantity constraints in PLUS. Spatial allocation was further controlled by historical neighborhood effects, land-use transition rules, and spatial constraints, including the ecological conservation redline. Thus, the simulated 2035 land-use patterns reflected the combined effects of scenario-specific land demand and spatial allocation rules. The land-use conversion cost matrix was adapted from previous research [
40] to reflect the conservation and development constraints of the study area (
Table 6).
Simulation performance was evaluated using the Kappa coefficient, Overall Accuracy (OA), Figure of Merit (FoM), Quantity Disagreement (QD), and Allocation Disagreement (AD).
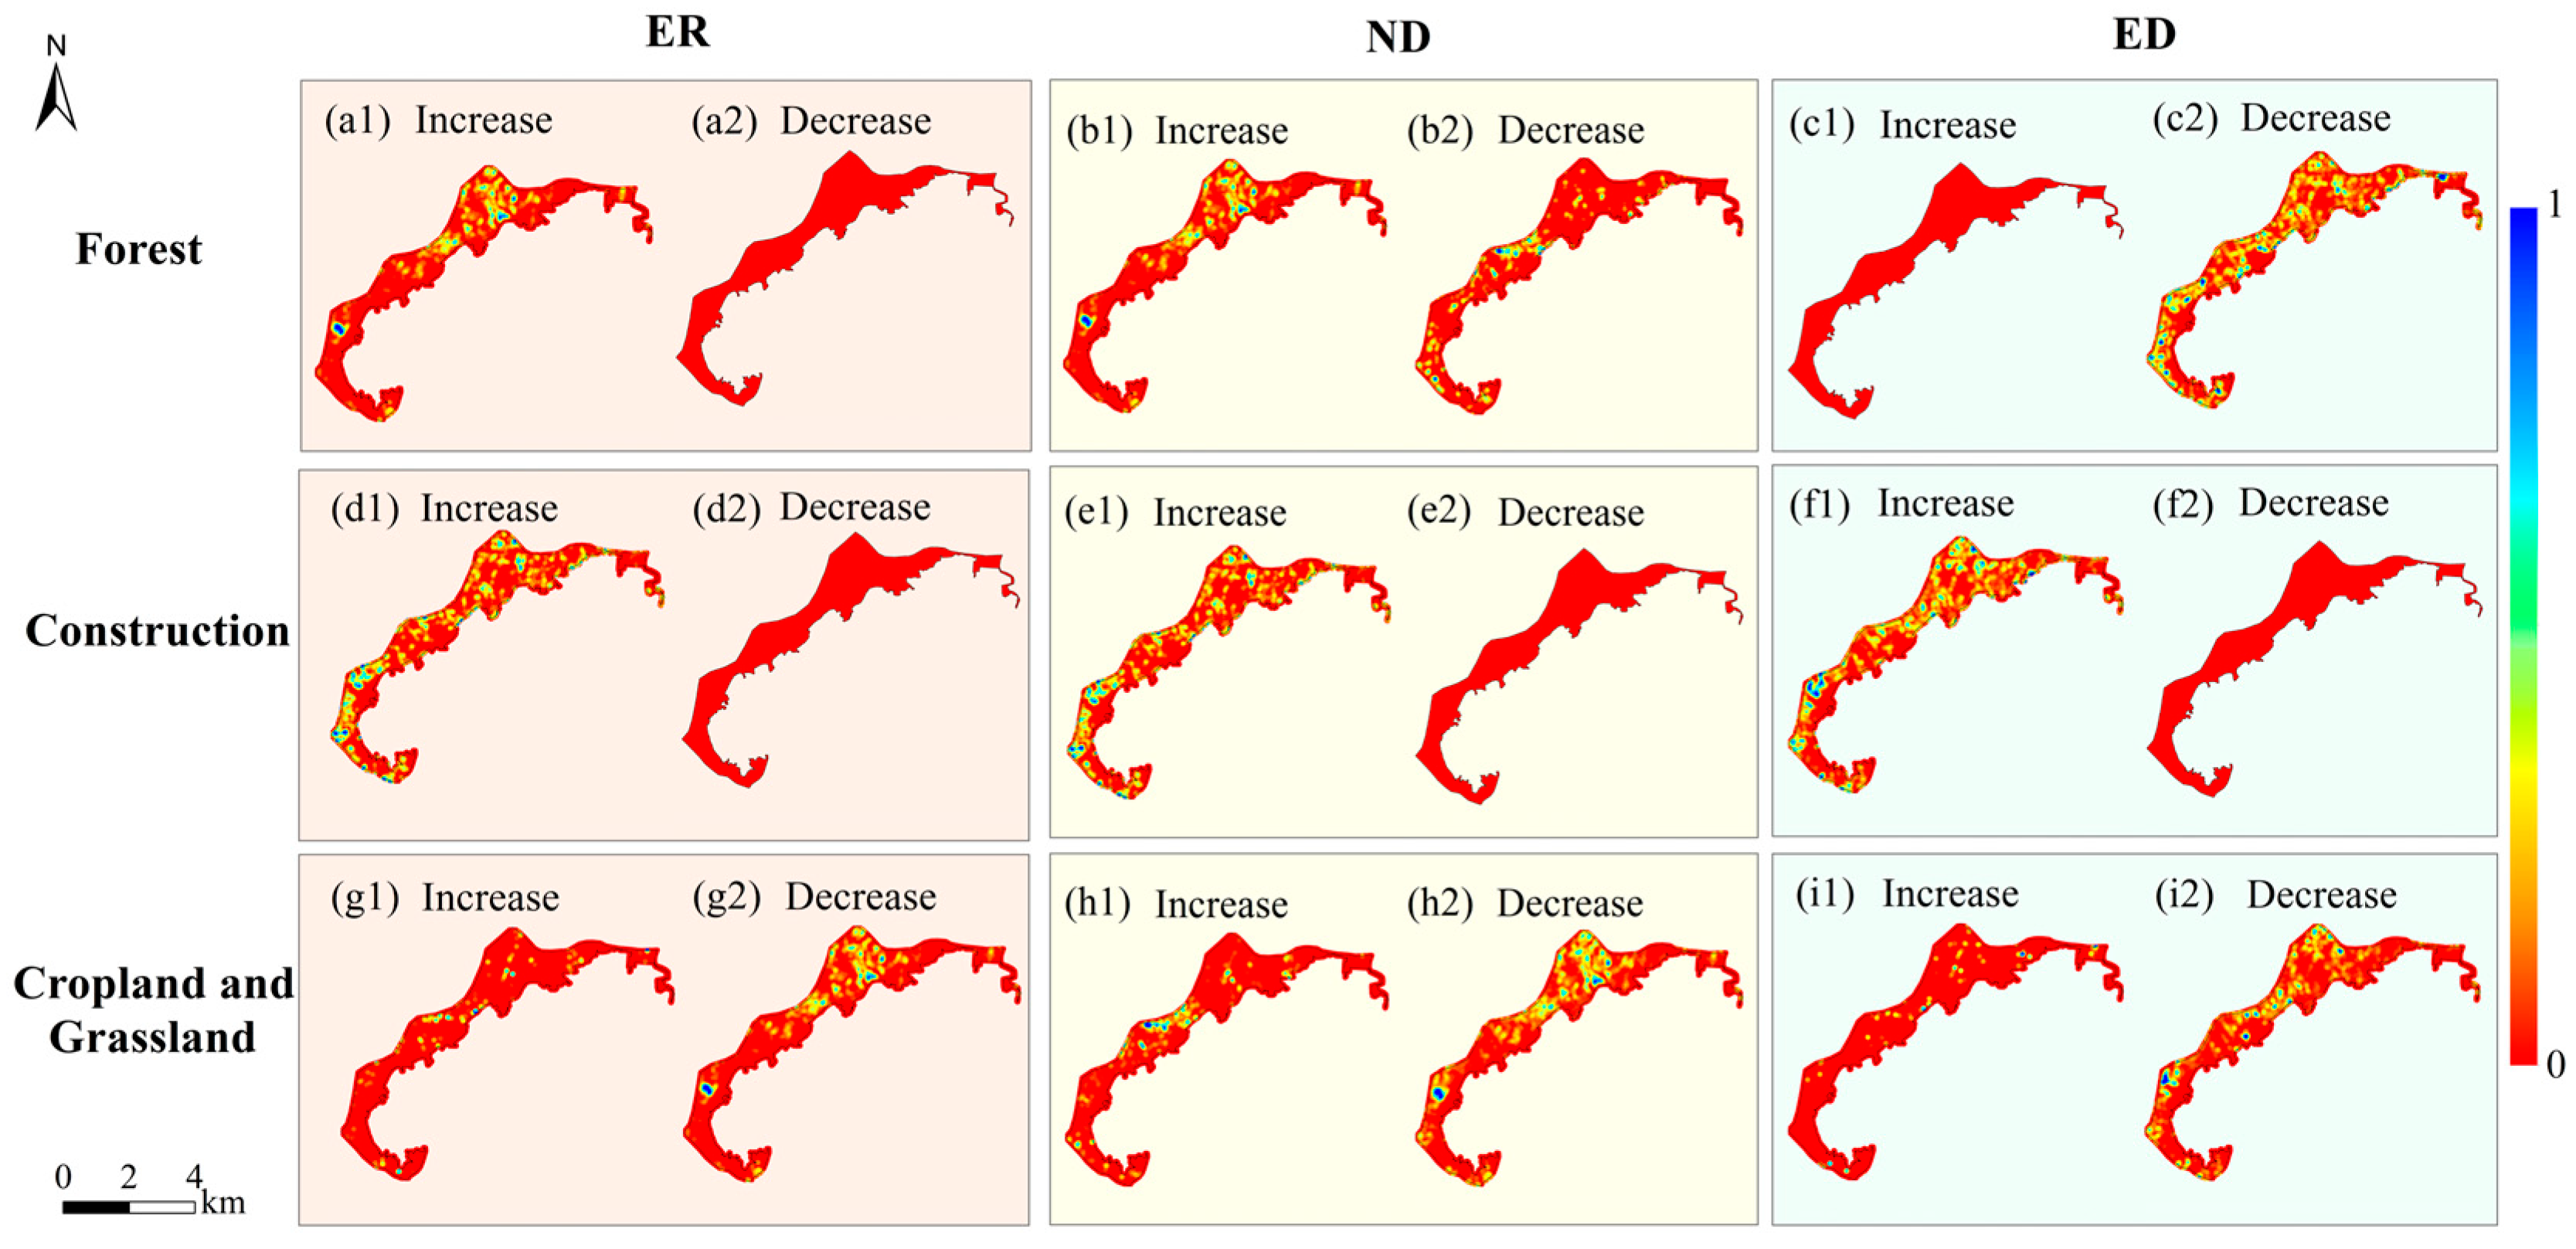
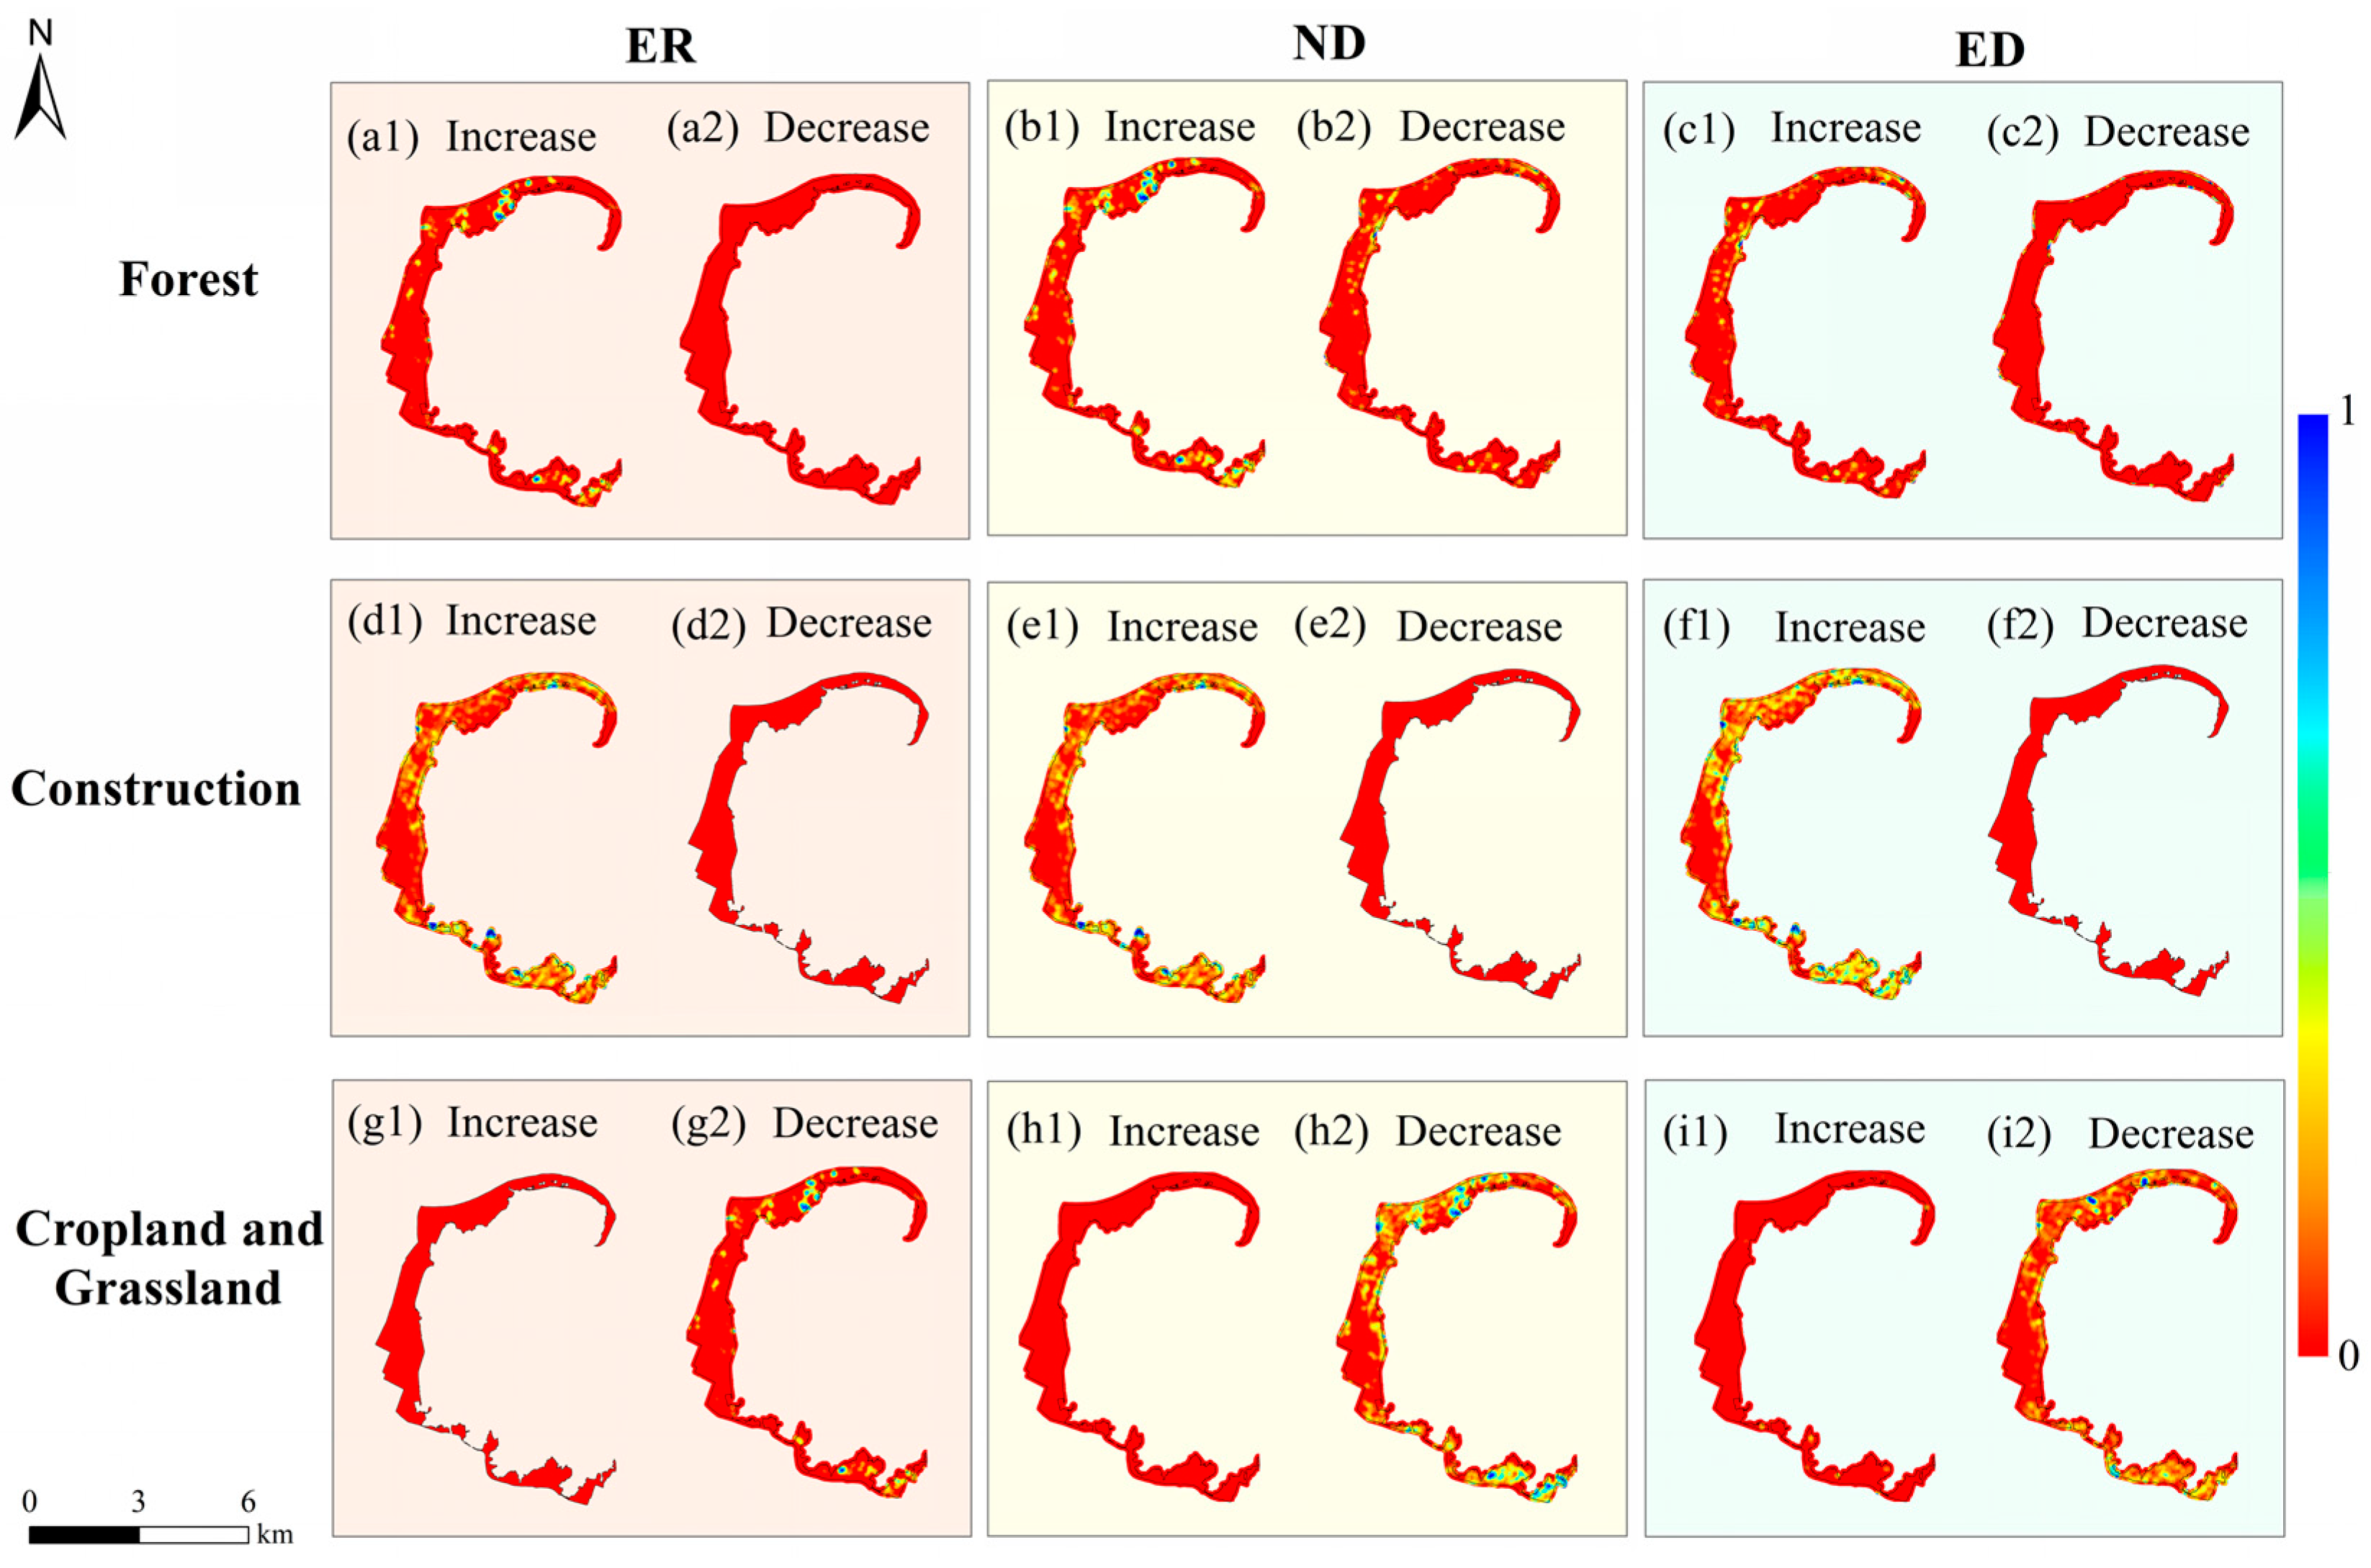
To characterize the local aggregation of major conversion processes, Boolean raster algebra was used to extract pixels that changed into or out of each class from 2024 to 2035. Target conversion pixels were assigned a value of 1, and all other pixels were assigned a value of 0. A focal mean was then calculated using a circular neighborhood with a 40-pixel radius (80 m). Local land-use conversion intensity was defined as the proportion of target conversion pixels among all valid pixels in the neighborhood. The metric ranged from 0 to 1, with higher values indicating greater local concentration of the corresponding conversion. The same raster resolution, neighborhood extent, and calculation method were used for both bays and all three scenarios.
2.3.5. Multi-Scenario Spatial Divergence and MMU Sensitivity Test
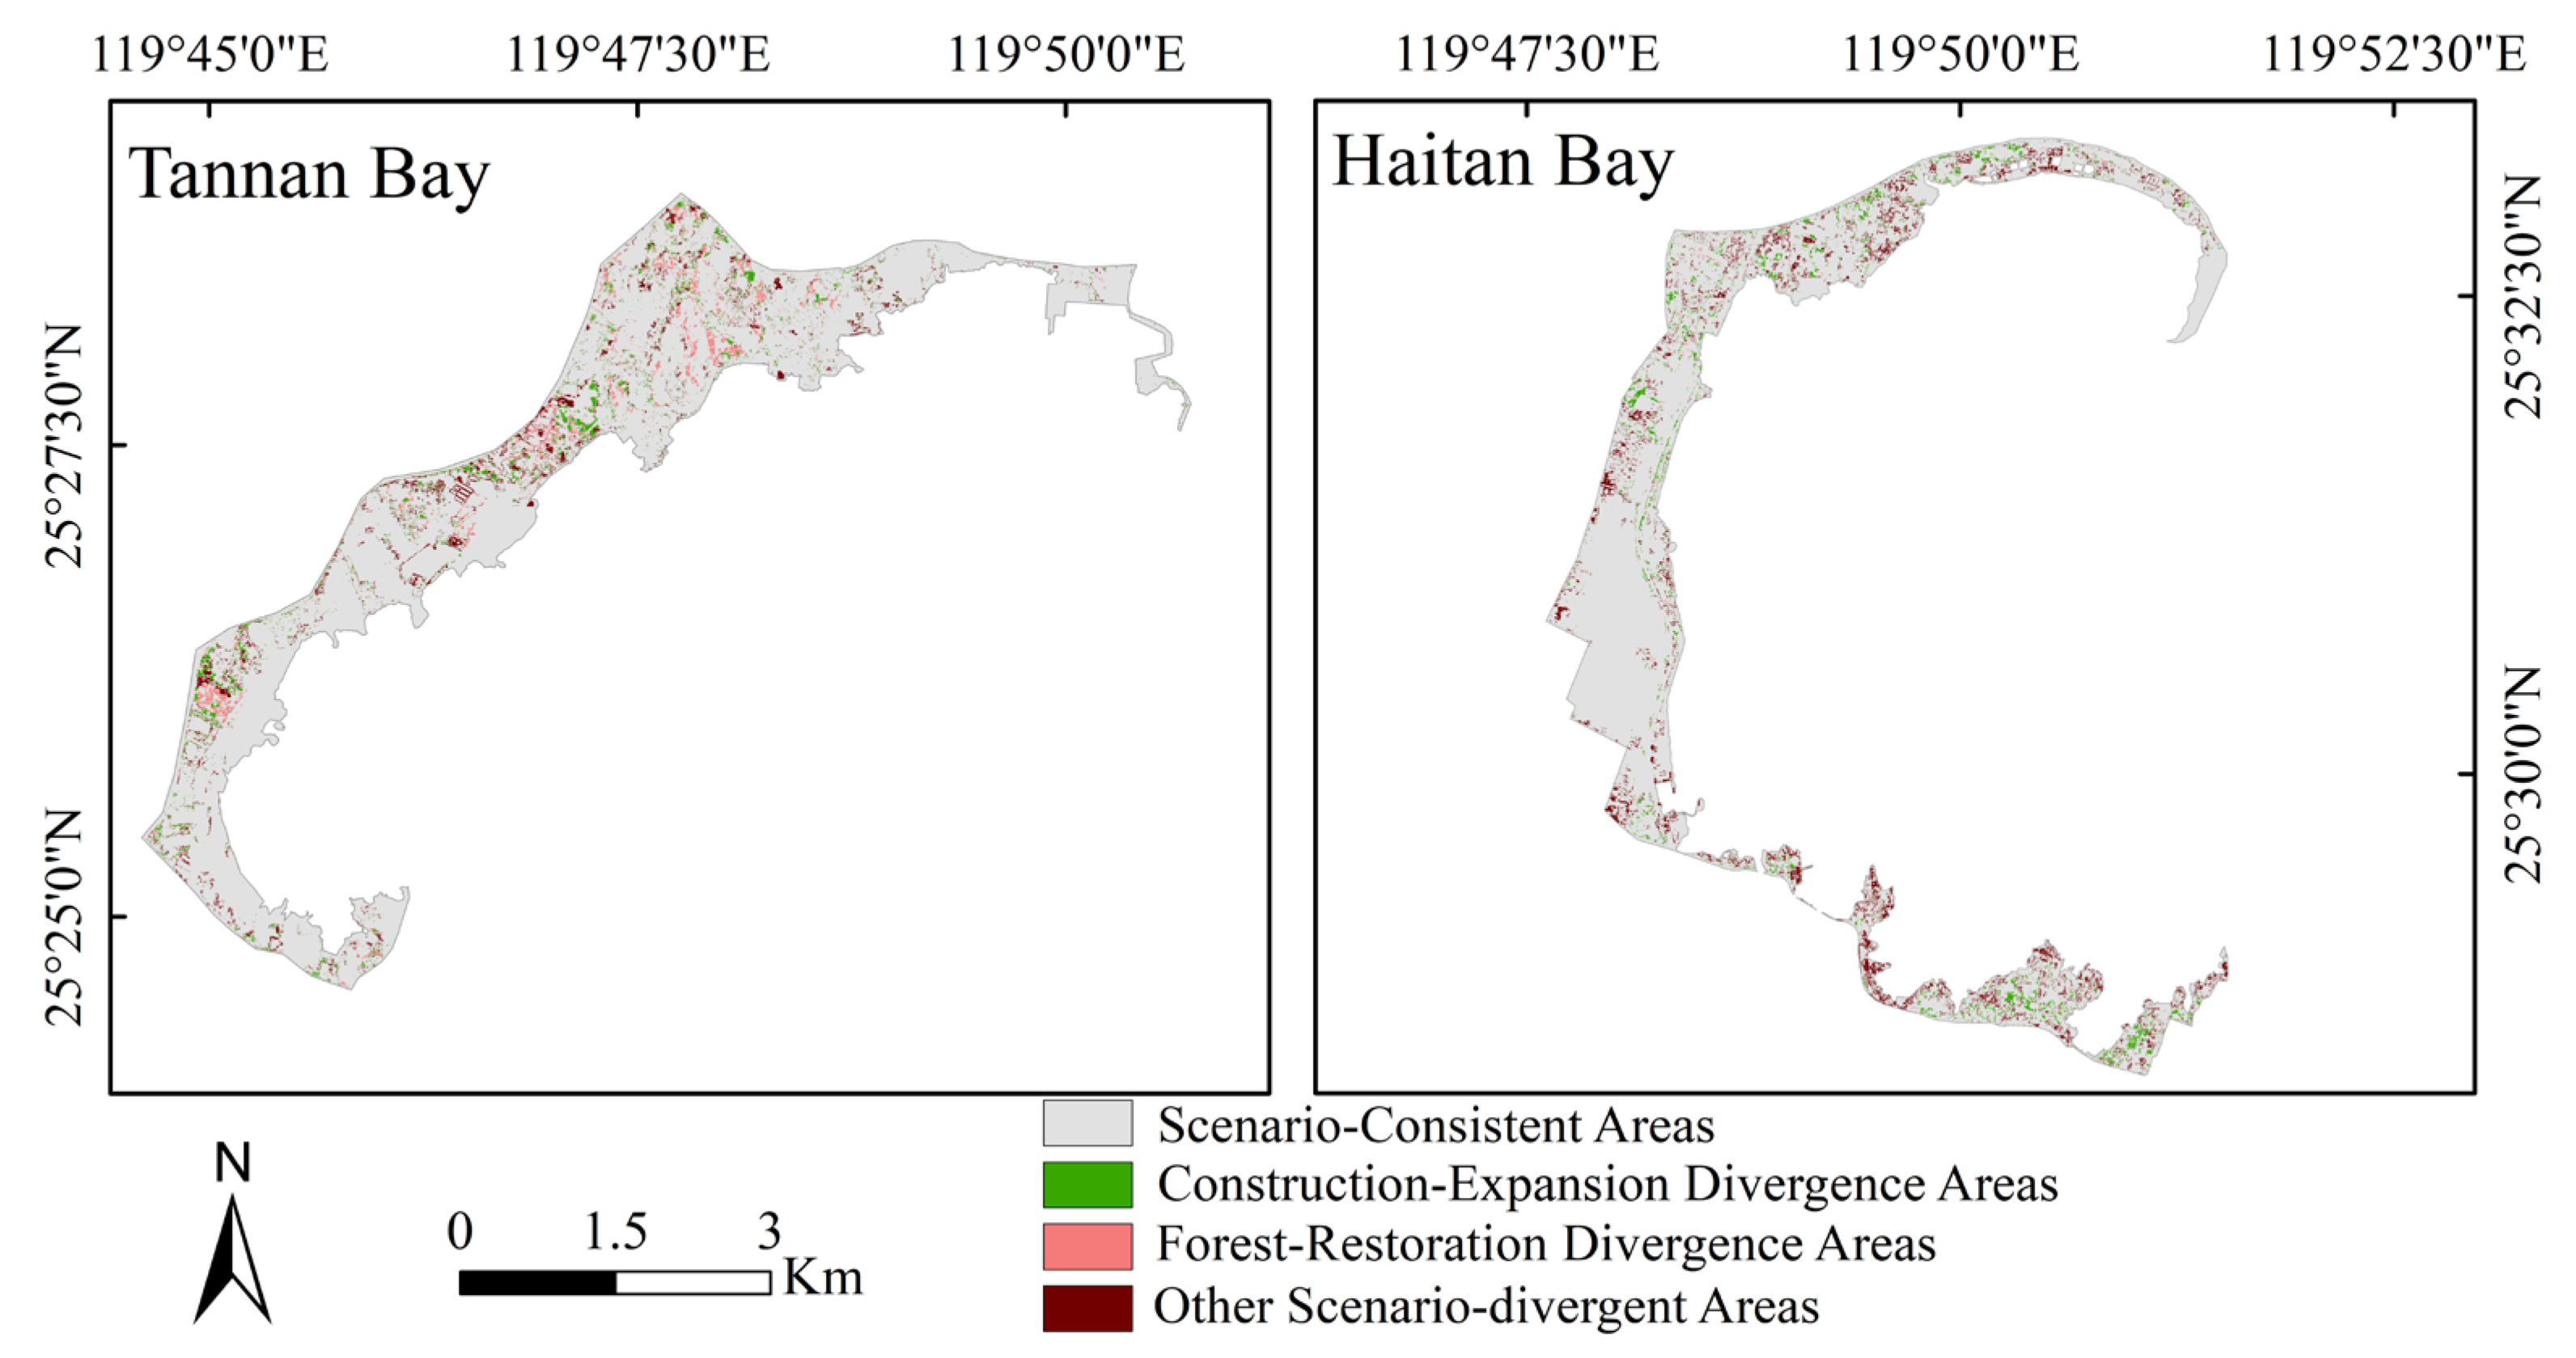
To identify spatial land-allocation differences between policy orientations, ER and ED in 2035 were overlaid pixel by pixel. ER and ED were selected for the spatial-divergence analysis because they represent the contrasting ecological-conservation and development-oriented policy settings, whereas ND served as the baseline scenario for comparing overall land-use responses. The 2035 ER and ED maps used in this pixel-by-pixel comparison each represent a single CARS simulation realization. The overlay was divided into four classes according to the land-use type assigned to each corresponding pixel. Scenario-consistent Areas had the same land-use type in both scenarios. Construction-Expansion Divergence Areas comprised pixels assigned as Construction Land under ED but as Forest Land or Cropland and Grassland under ER. Forest-Restoration Divergence Areas comprised pixels assigned as Forest Land under ER but as Cropland and Grassland or Other Land under ED. Other Scenario-Divergent Areas comprised all remaining pixels with different land-use types between the scenarios. Because this last class included land-use combinations with inconsistent directions, it was not a focus of comparisons of construction expansion and forest restoration.
Contiguous patches were identified using the 8-neighbor rule. Area Proportion, Number of Patches (NP), PD, Mean Patch Area (AREA_MN), and Largest Patch Share (LPS) were calculated under three MMU settings. These were No MMU Filtering, ≥9 pixels (0.0036 ha), and ≥25 pixels (0.0100 ha). The MMU settings were selected by jointly considering the original spatial resolution and the analysis scale. Because the Scenario-Divergent Areas were identified by pixel-by-pixel overlay of 2 m rasters, relatively small MMUs were required to reduce the influence of very small pixel clusters on patch analysis while retaining as much spatial detail as possible from the high-resolution data [
41,
42]. On this basis, a 25-pixel threshold (100 m
2) was additionally adopted as a higher MMU level, which is consistent with the minimum mapping area specified for Construction Land and facility agricultural land in the Third National Land Survey of Fujian Province [
43]. LPS was calculated from the LPI and PLAND outputs from FRAGSTATS as follows:
where
is the largest patch area in scenario-zone class
as a proportion of that class’s total area (%).
is the Largest Patch Index of scenario-zone class
(%).
is the proportion of scenario-zone class
in the total study area (%). Area Retention Rate under different MMU settings was calculated as follows:
where
is the retained area under MMU setting
, and
is the unfiltered area.



 ,