Design and Implementation of a Low-Cost Perception System for Aerial Robots in Confined Spaces


Abstract
1. Introduction and Motivation
1.1. Quadcopter Design with Ducted Propellers
1.2. Work on Perception System
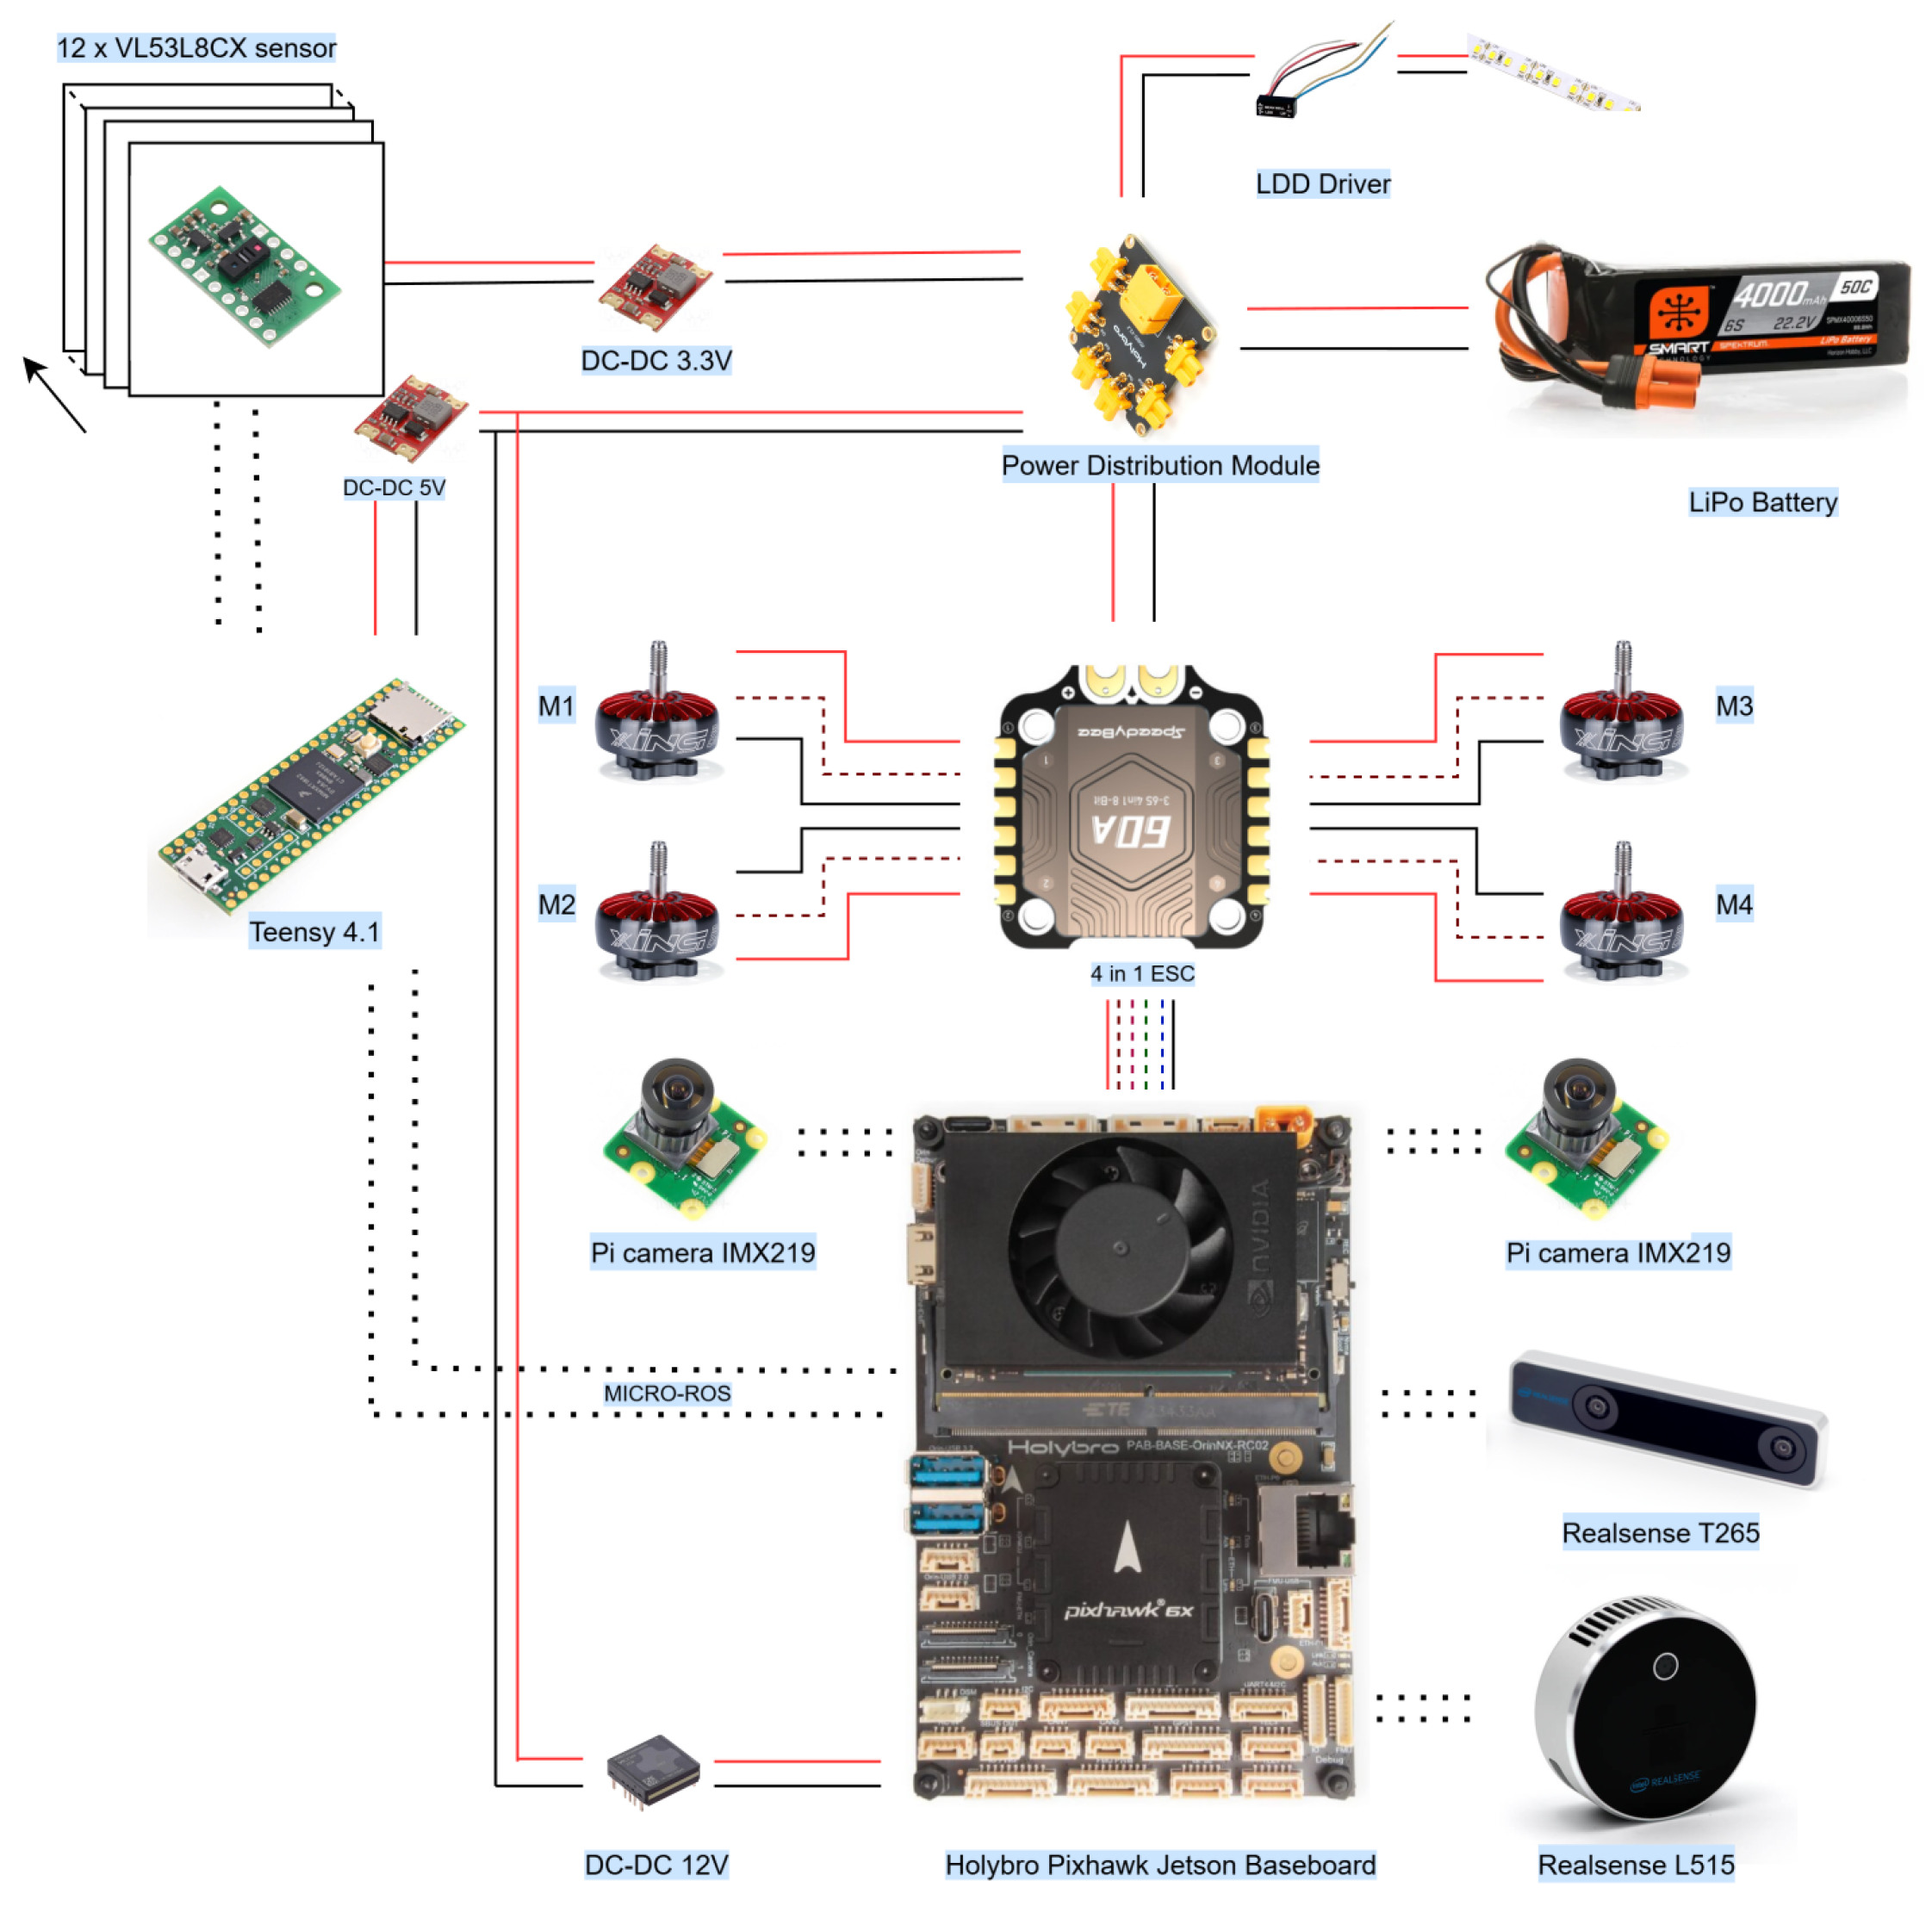
- Unique UAV Design: A novel UAV design and system architecture is proposed to tackle the problems encountered flying in a confined space optimally.
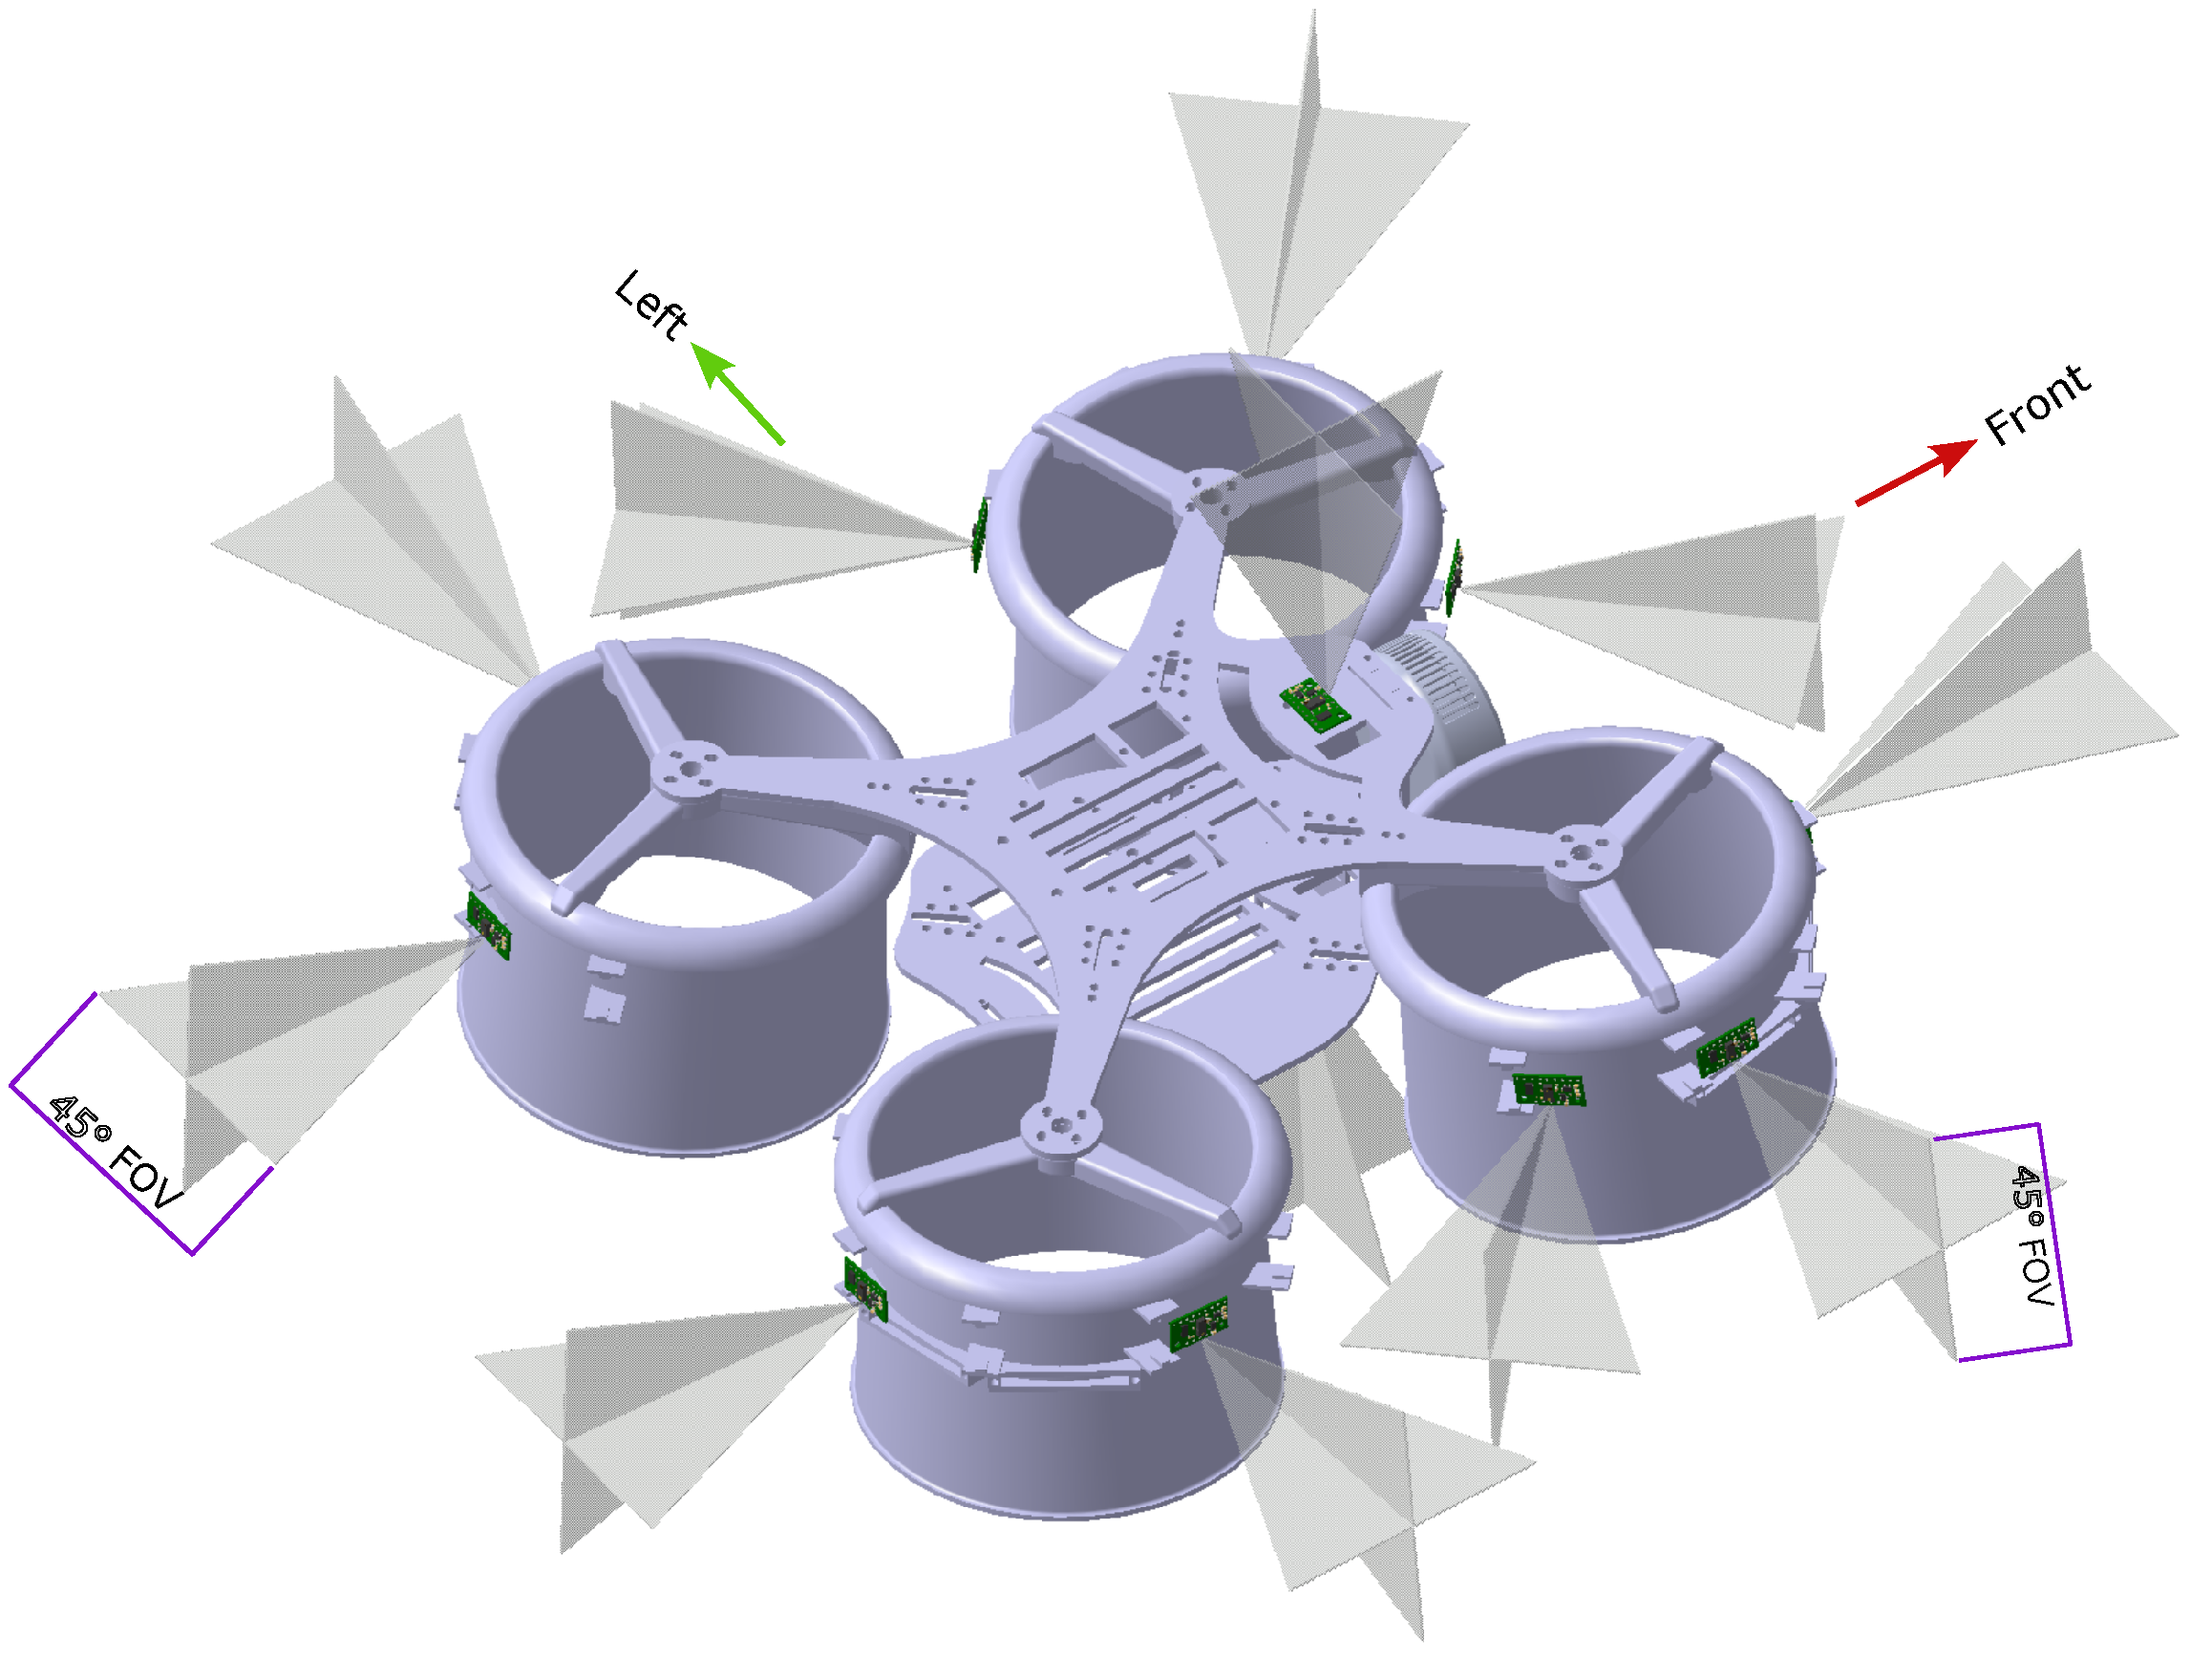
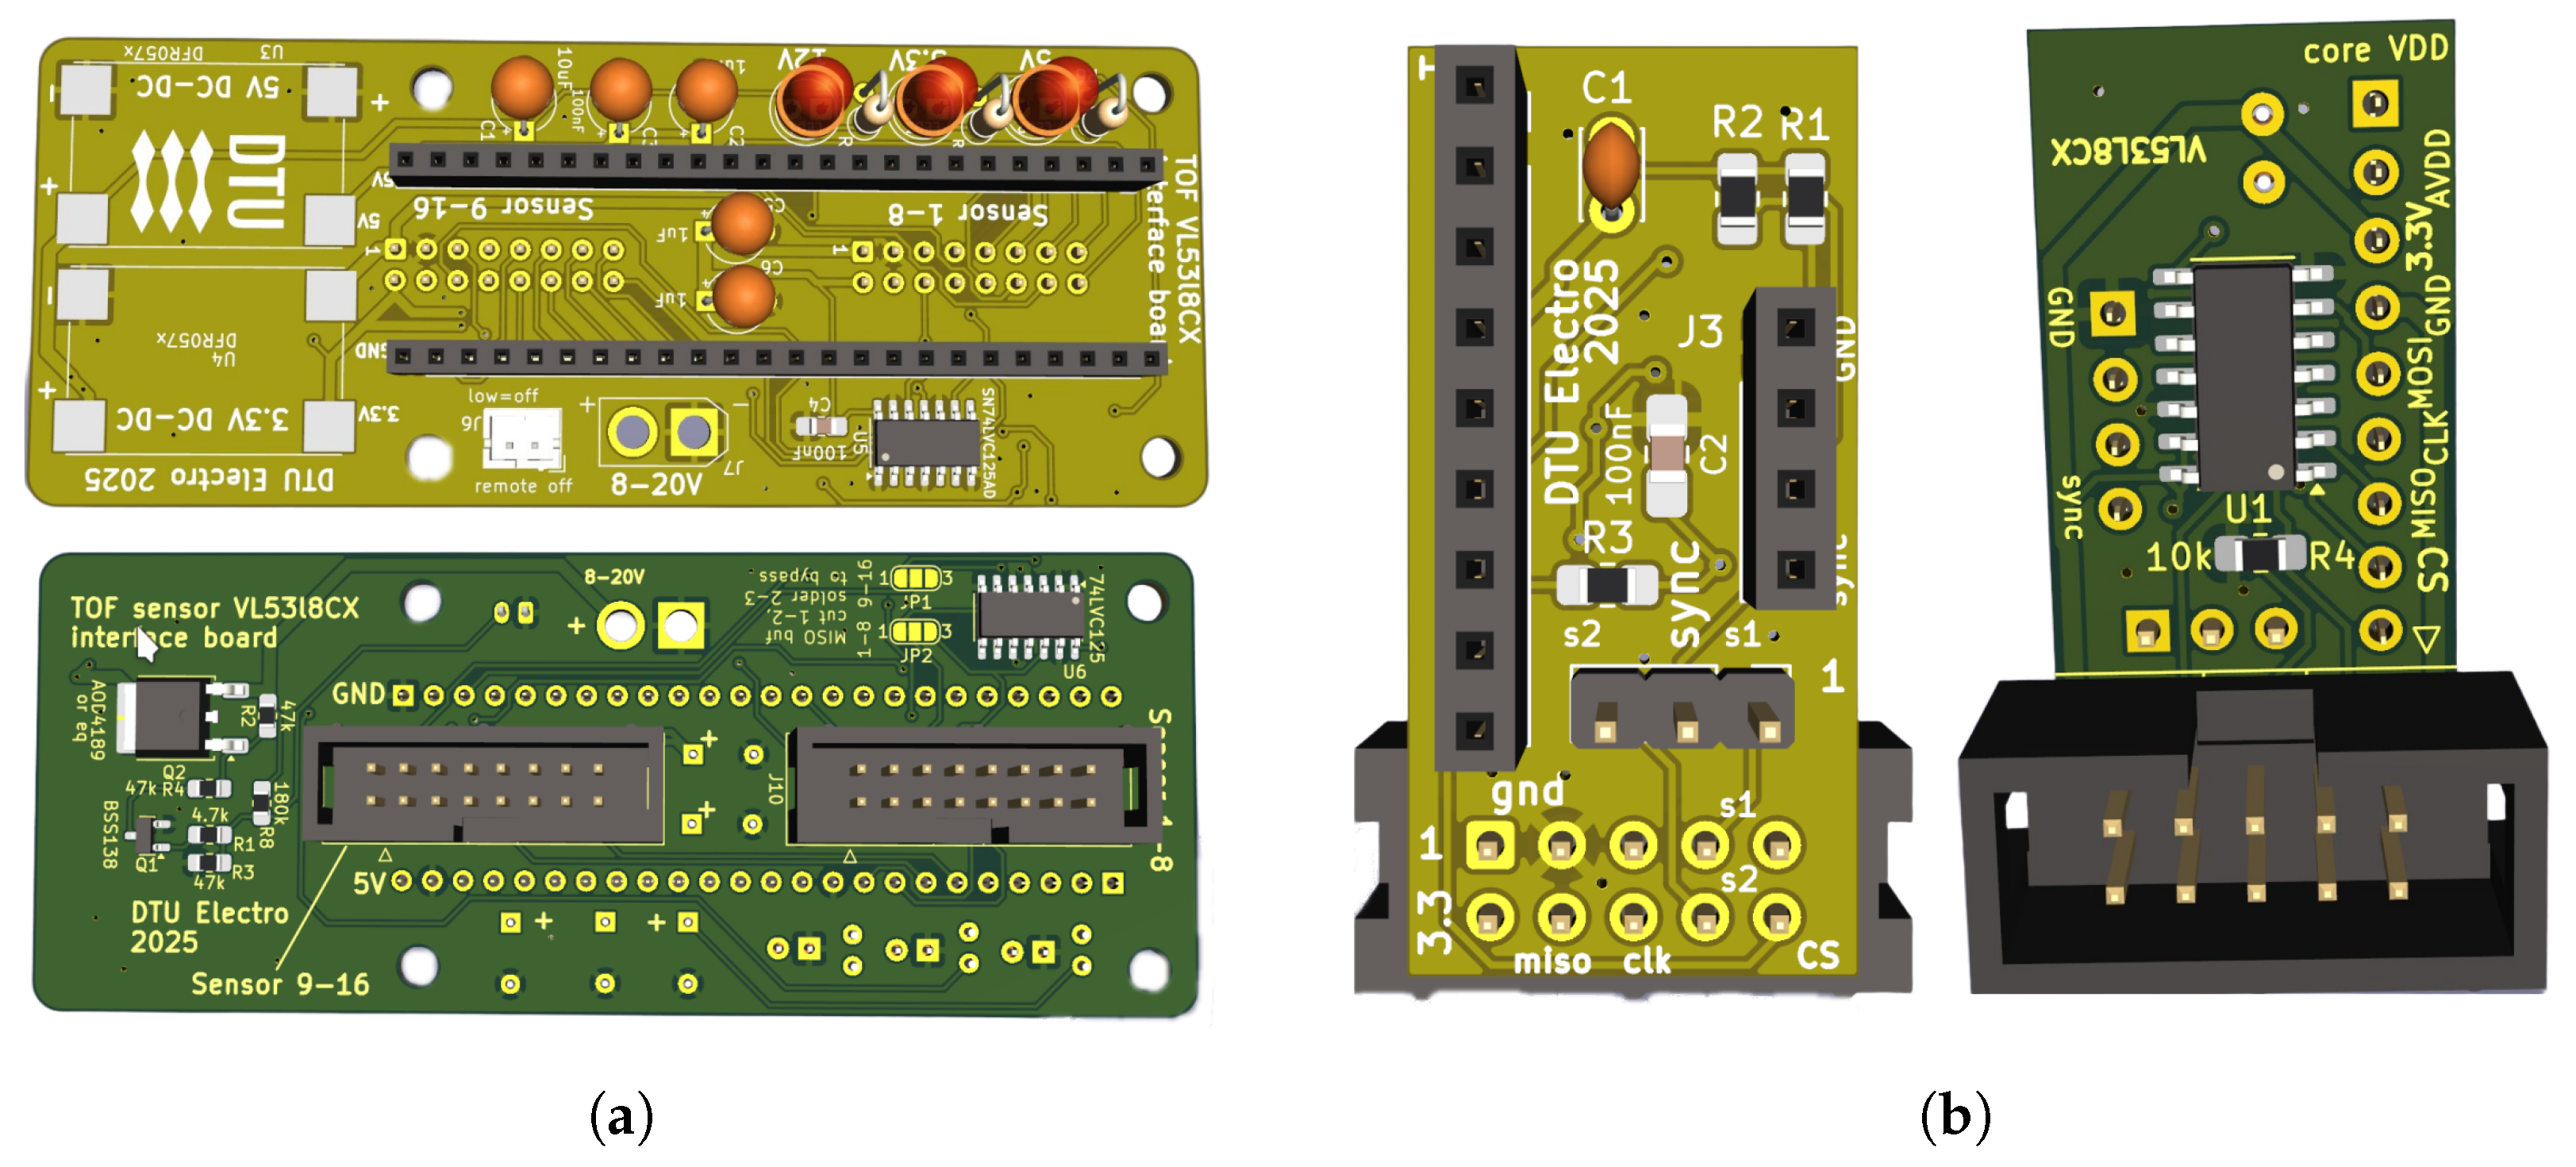
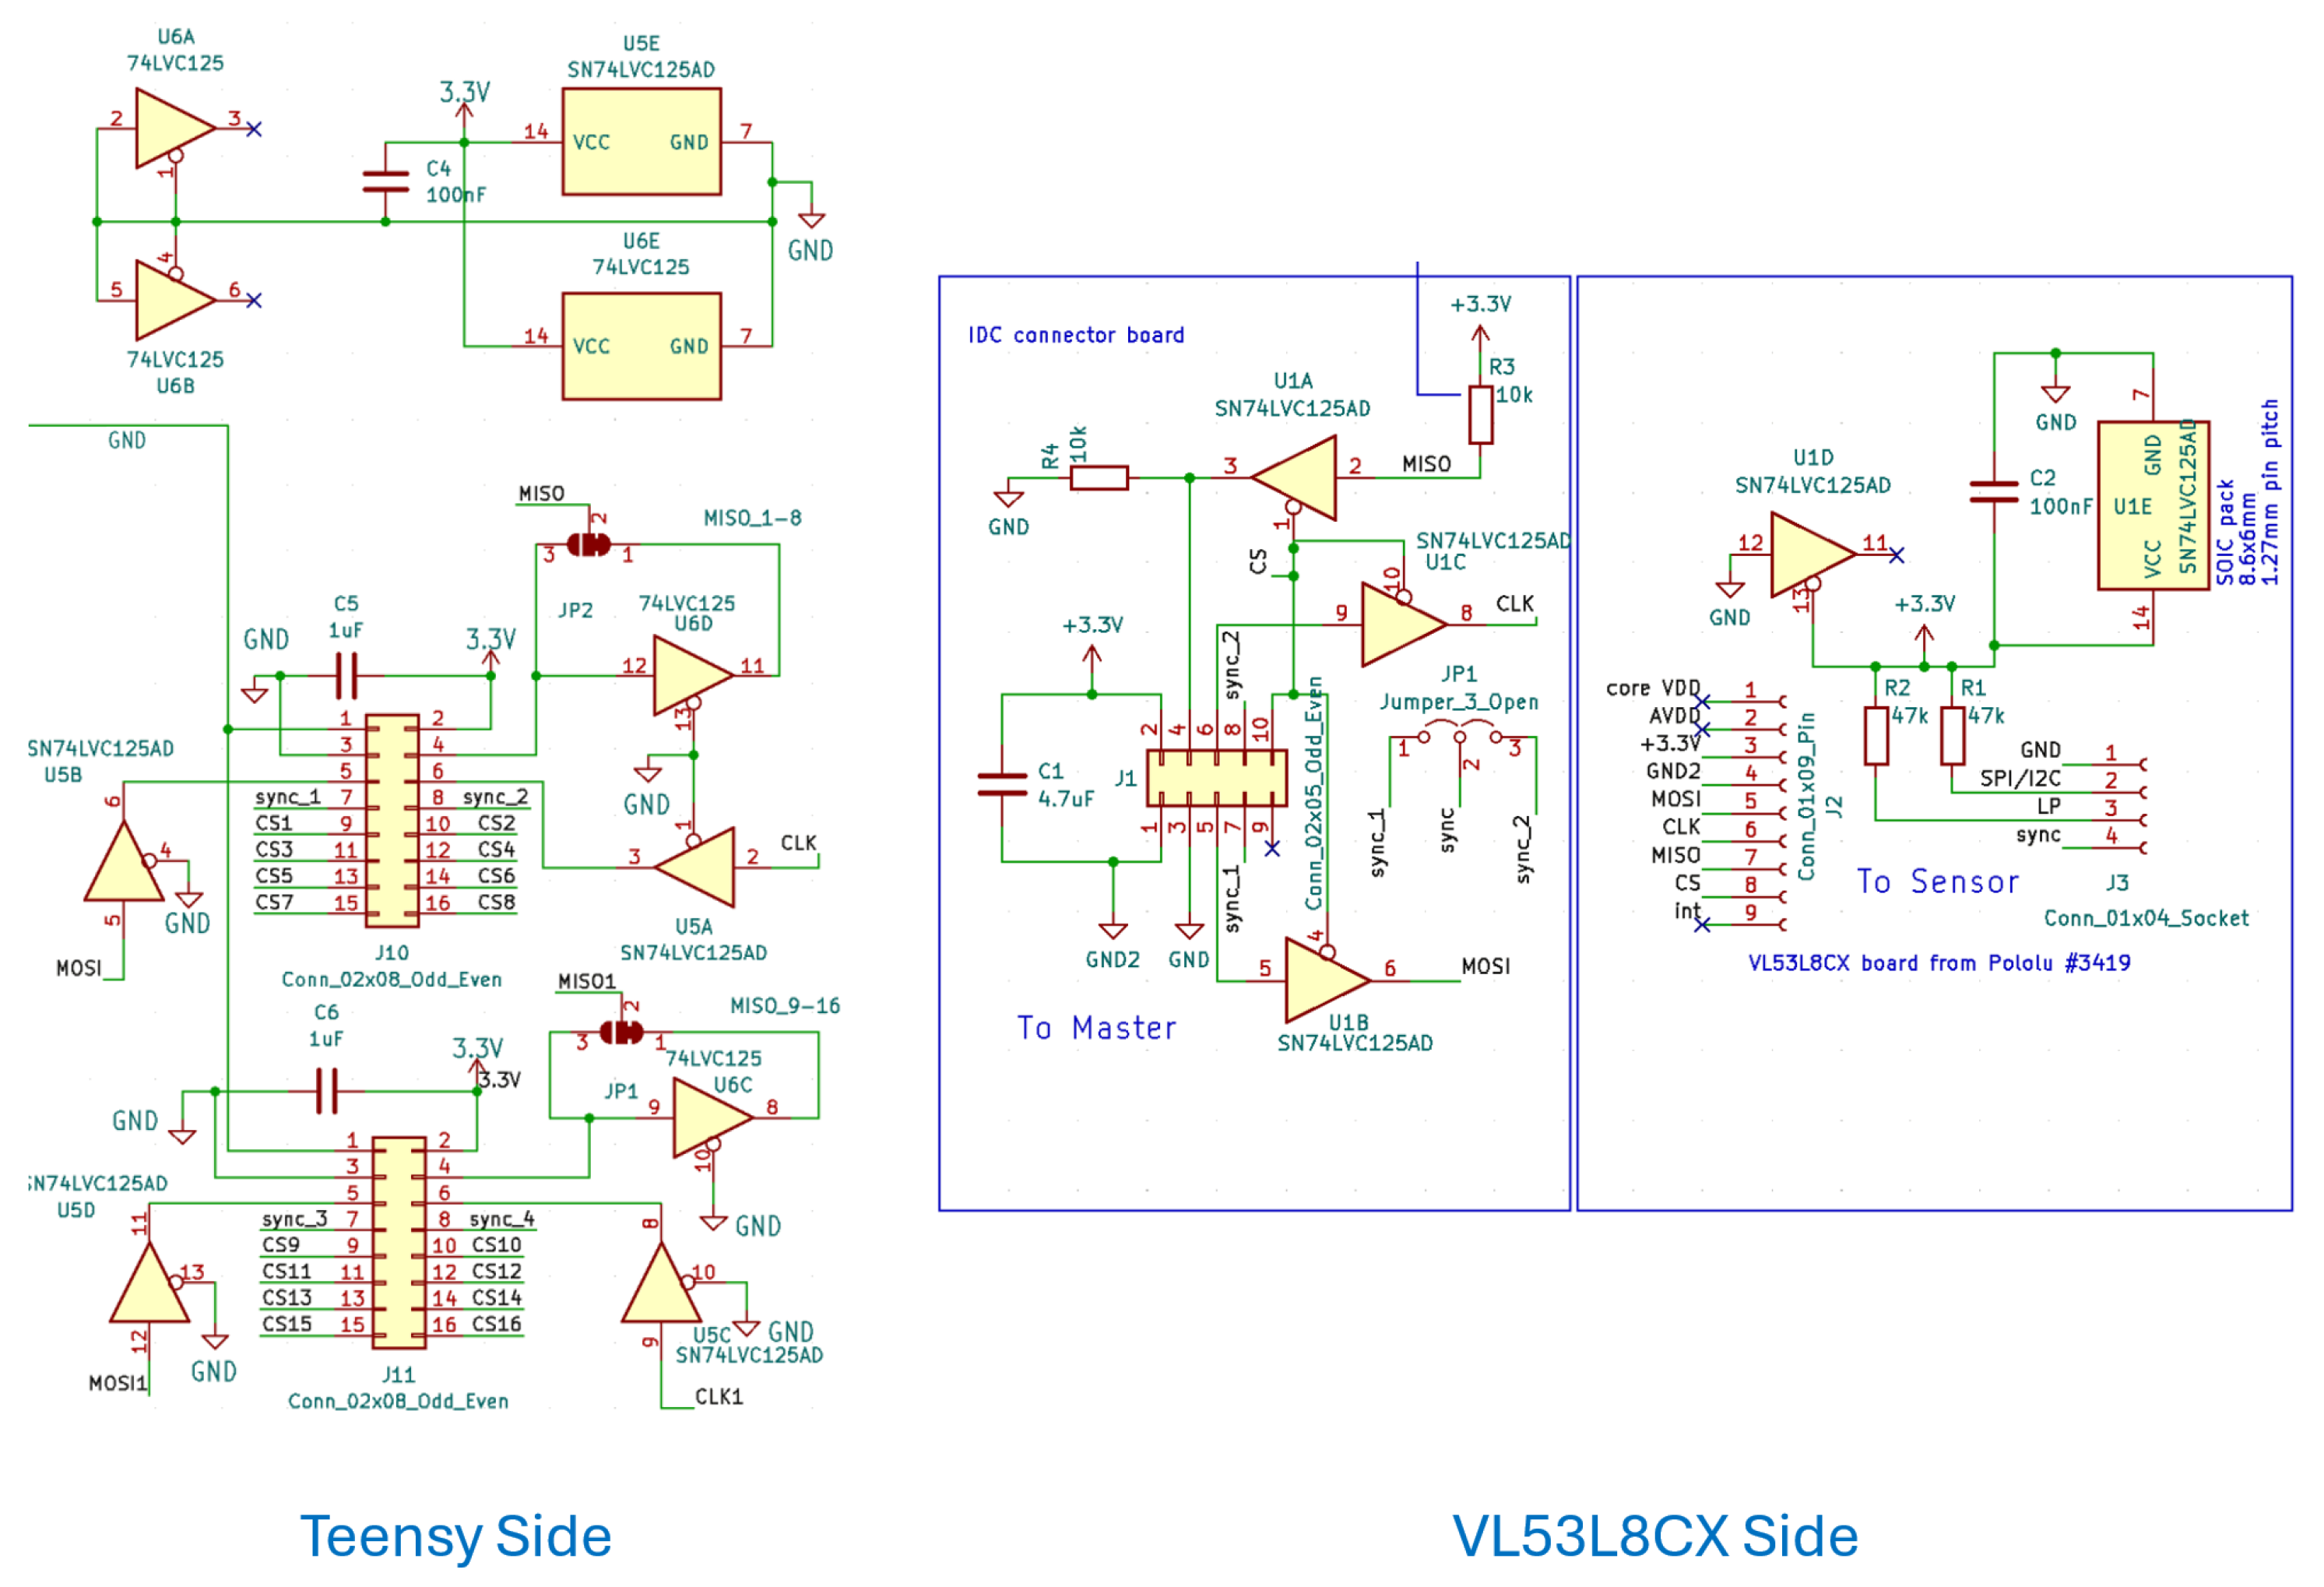
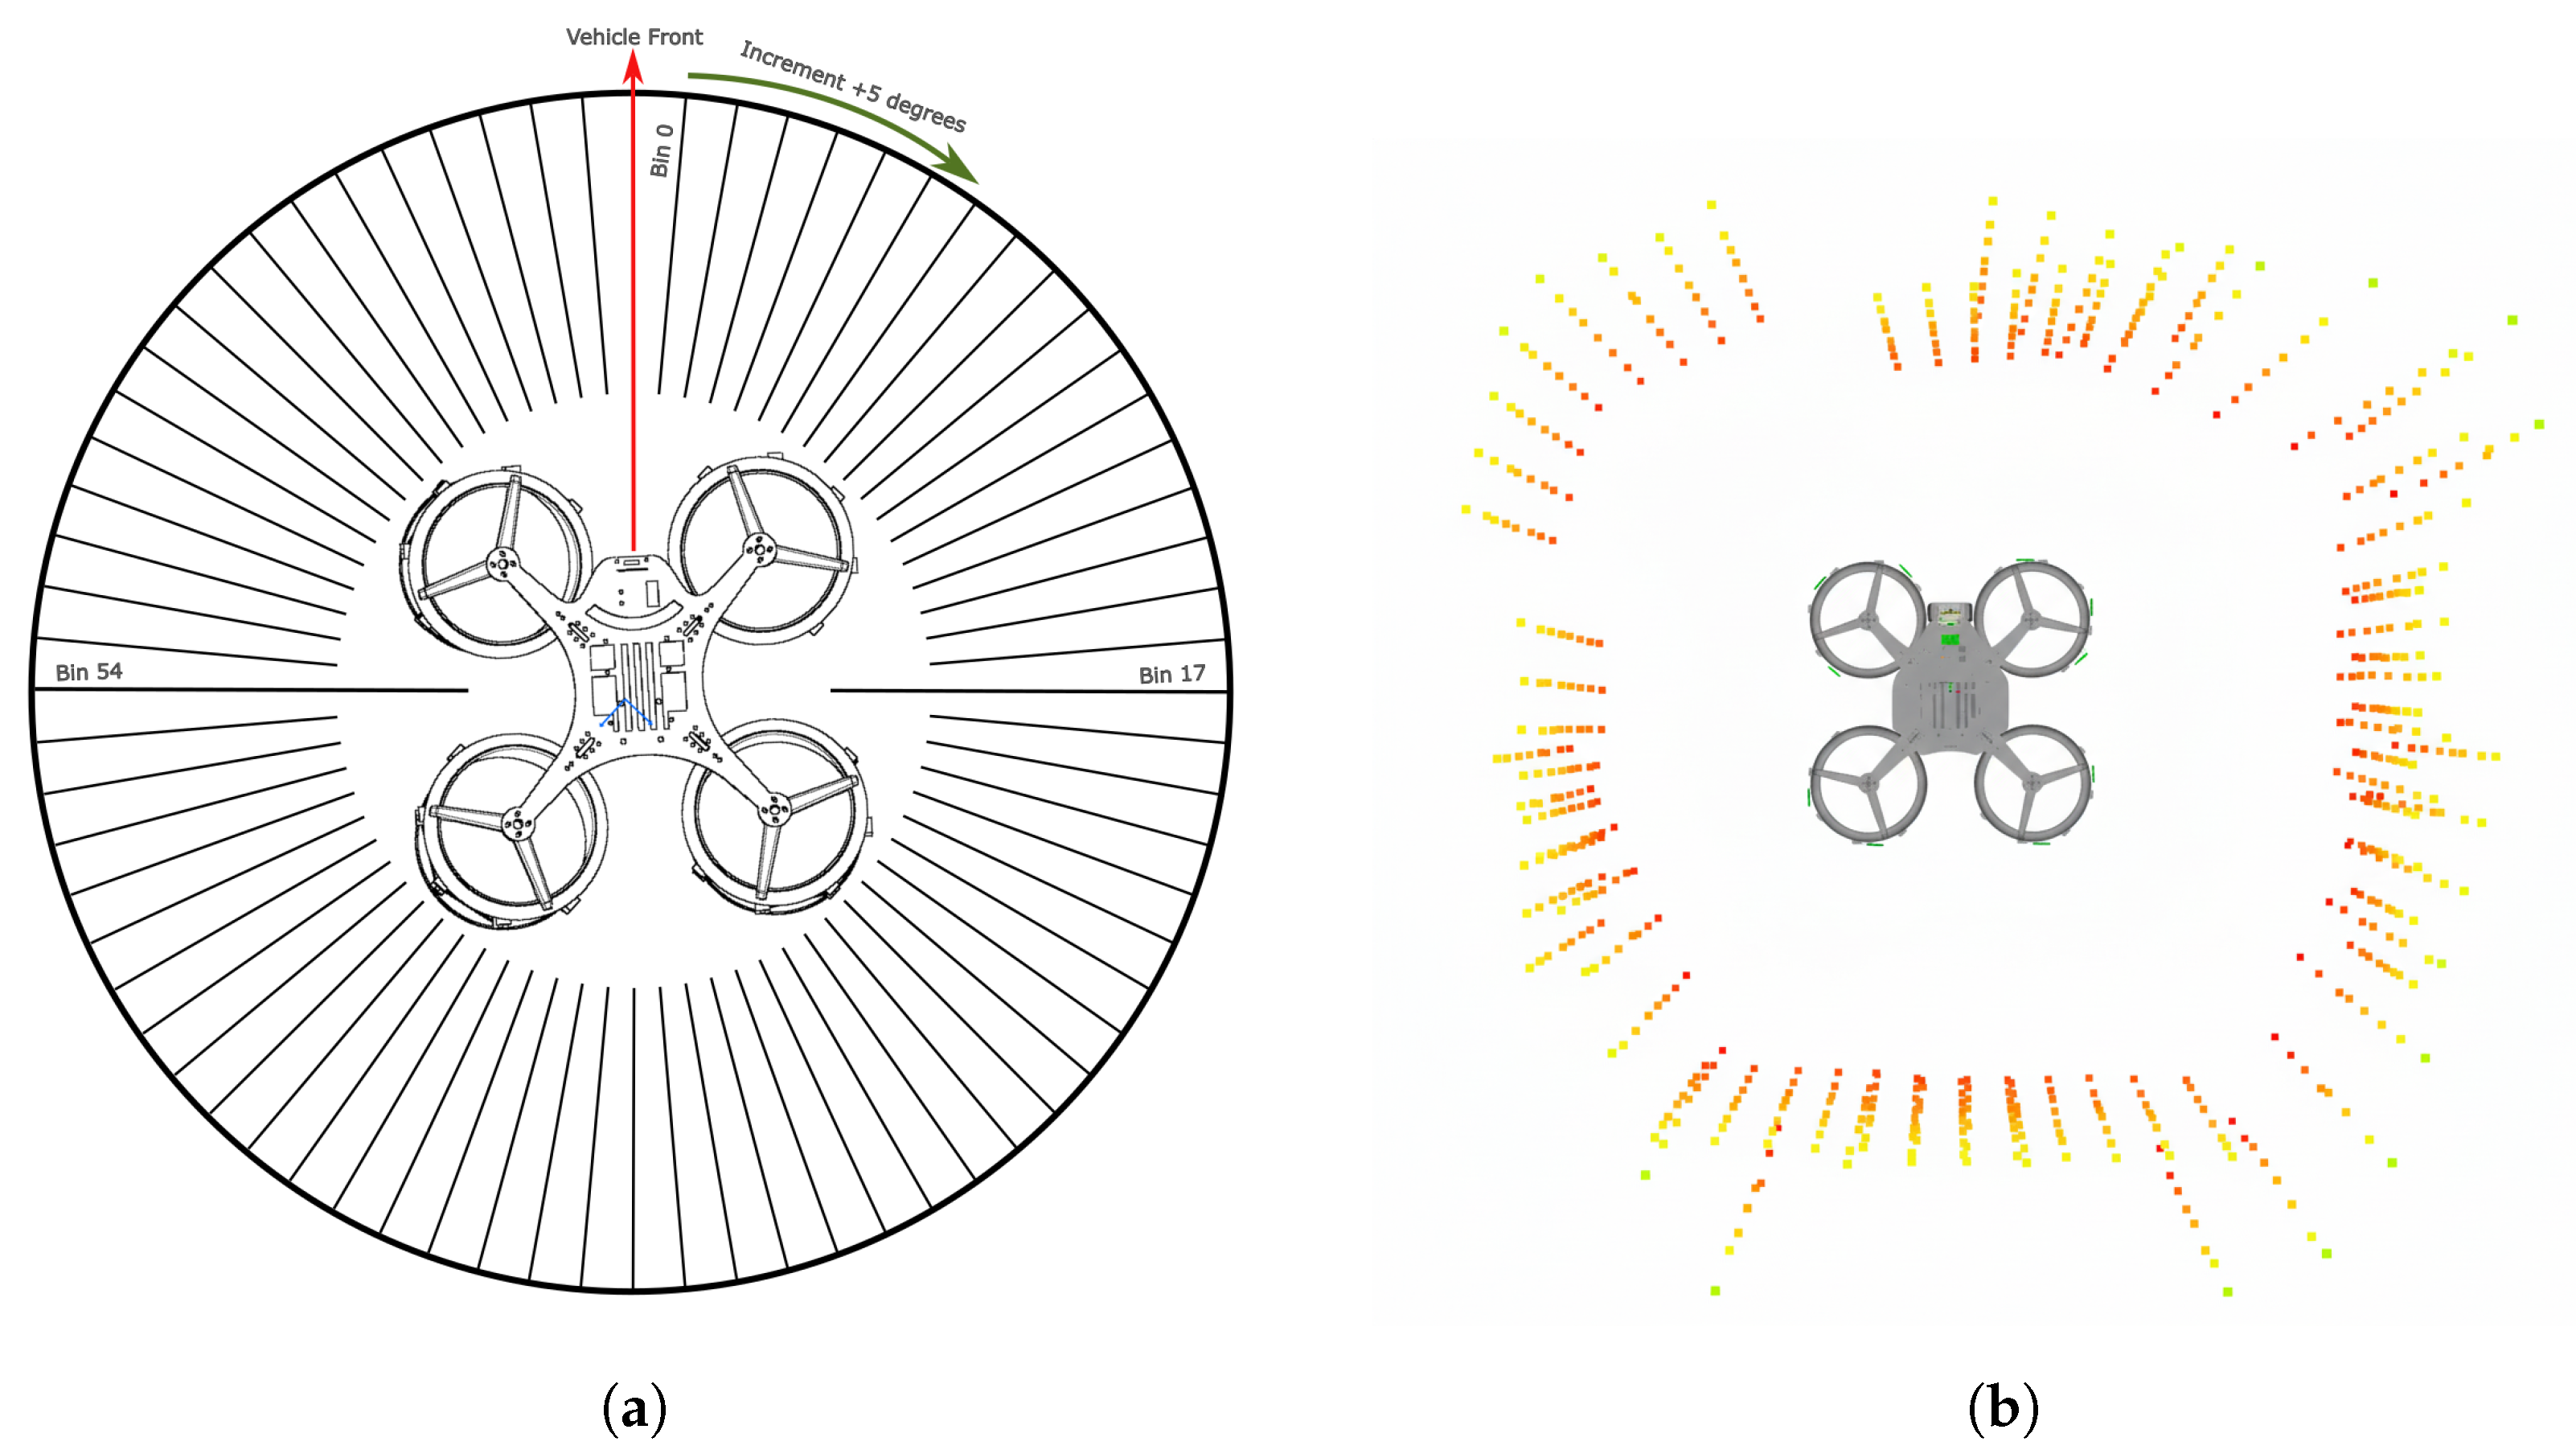
- Perception System: A unique system of 12 time-of-flight sensors (VL53L8CX) is designed for active perception around the UAV.
2. System Design
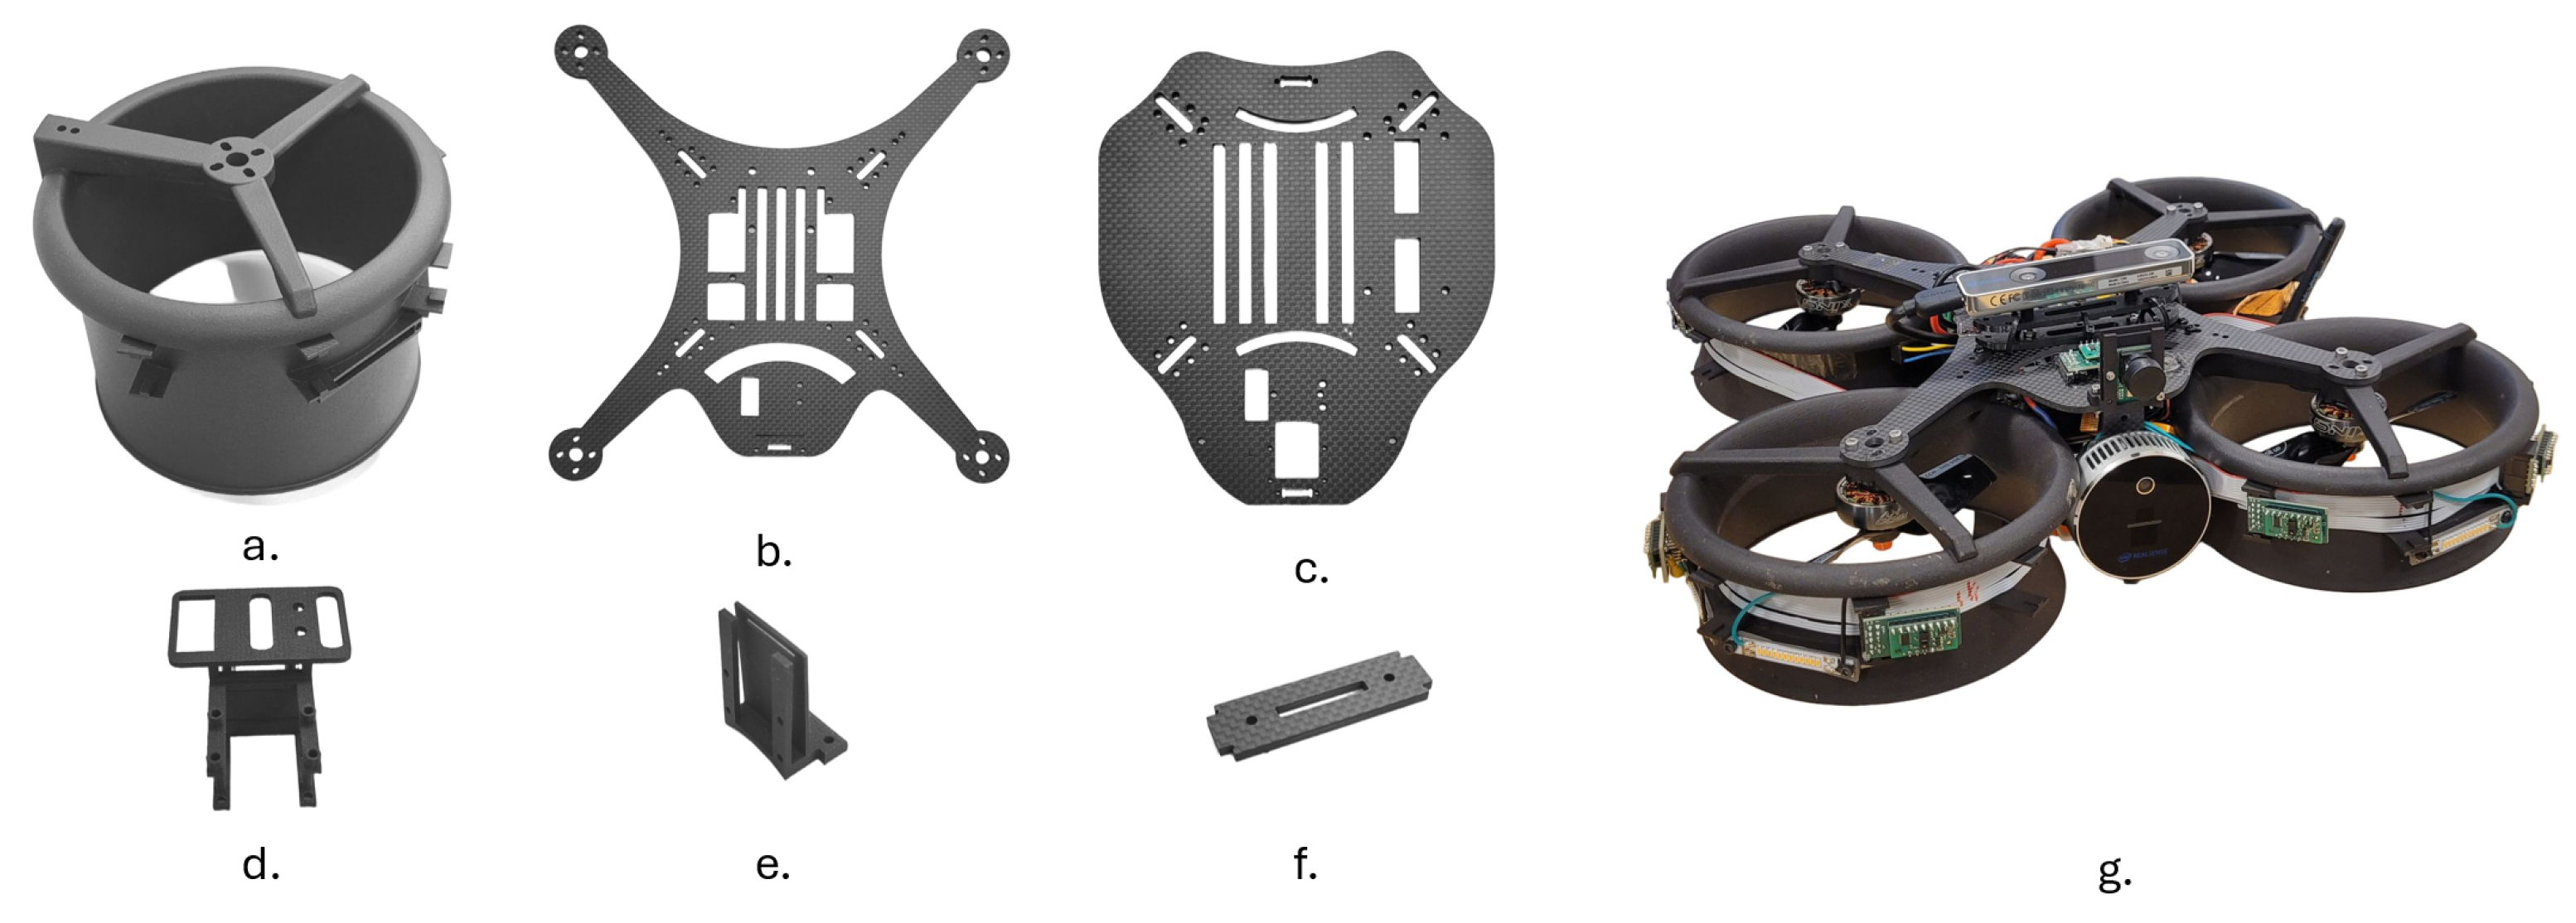
2.1. Airframe
2.2. ToF Multi-Zone Sensor
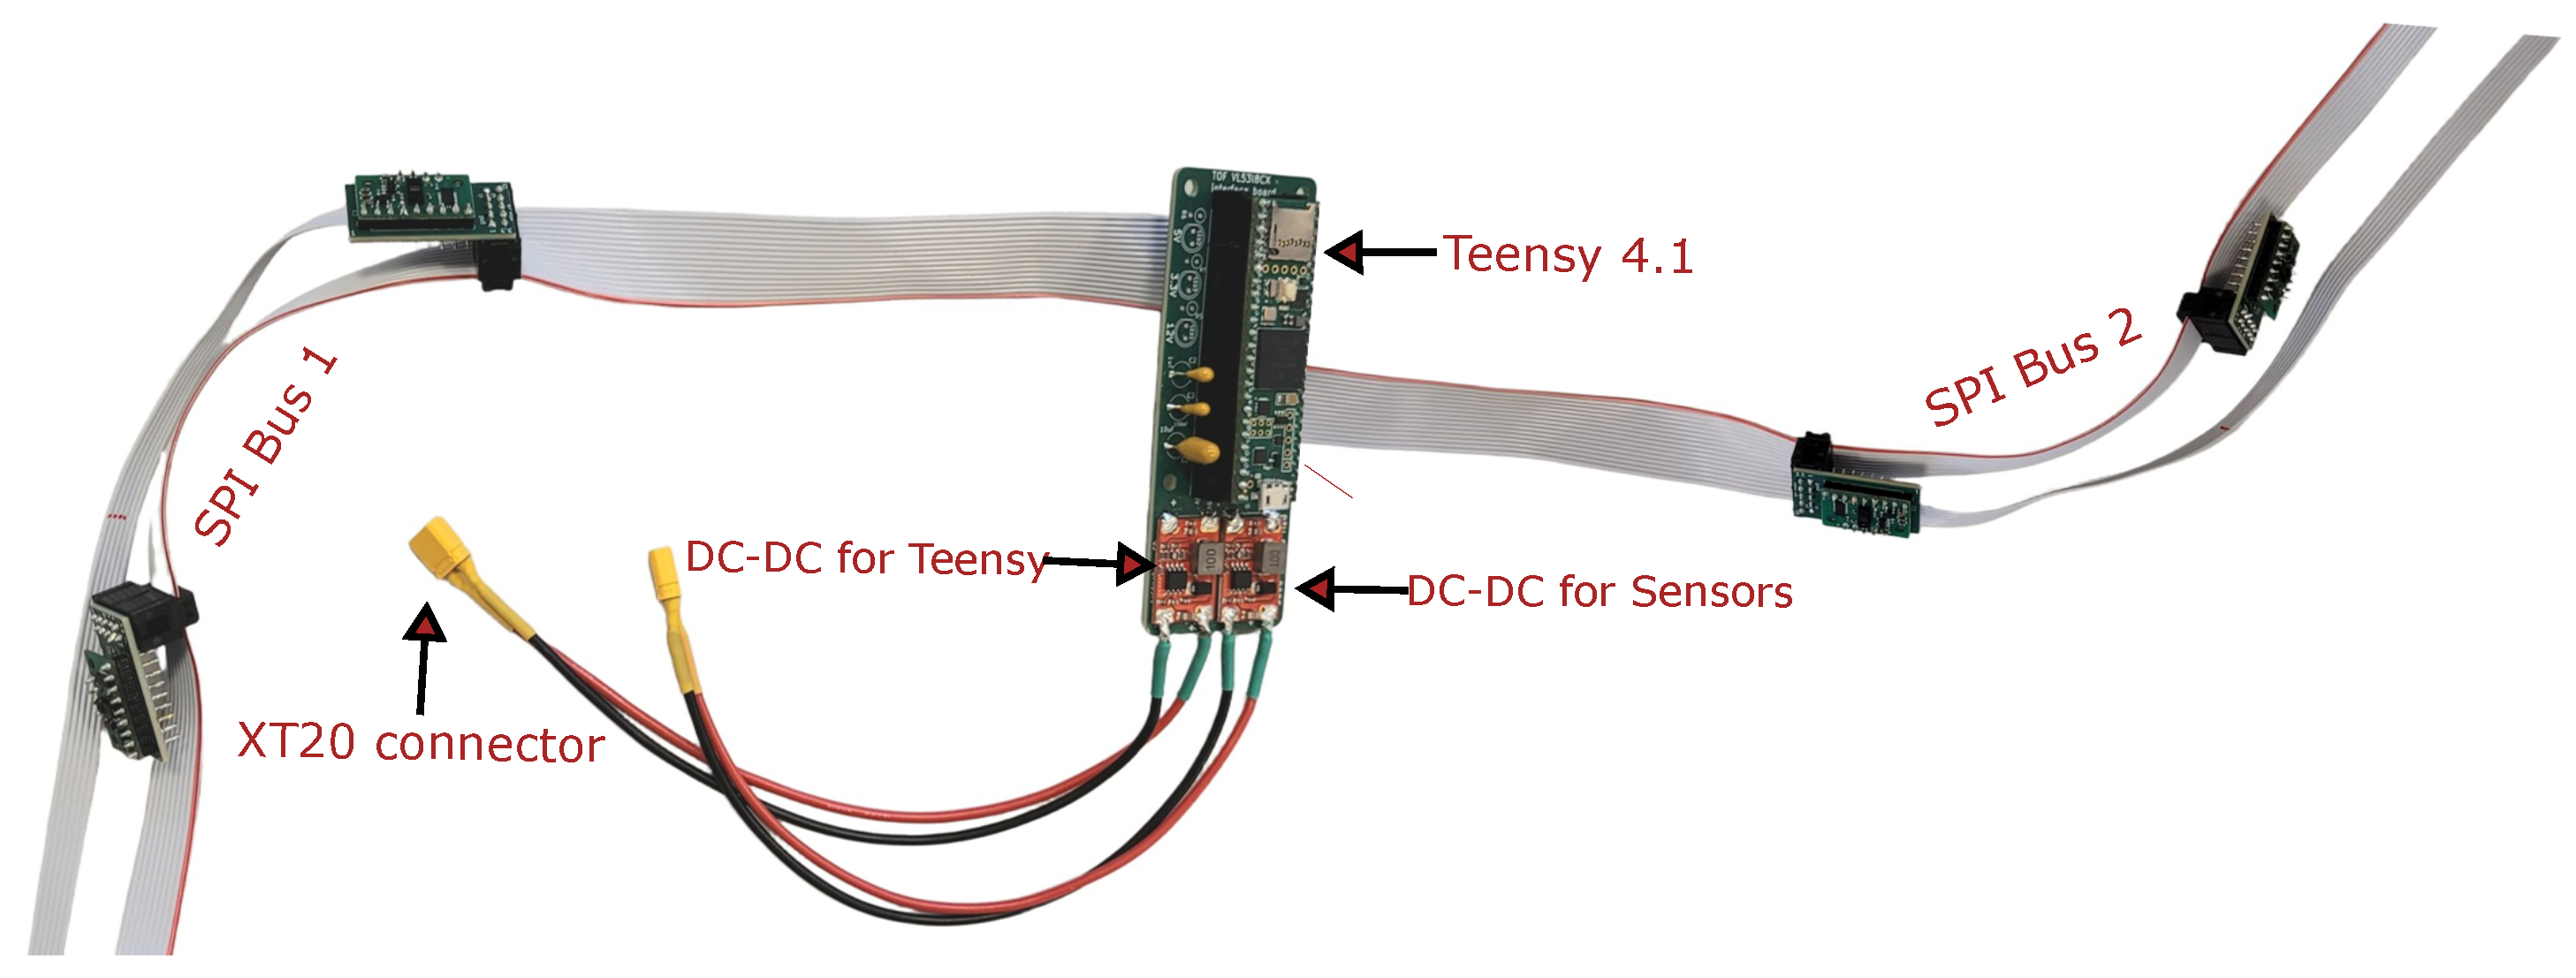
2.3. TOF Sensor Setup
3. Software-in-the-Loop (SITL) Simulation
3.1. PX4 SITL
3.2. PX4 SITL Gazebo Model
3.2.1. Projection Model of the Sensor
3.2.2. Rigid-Body Transformation to Base Frame
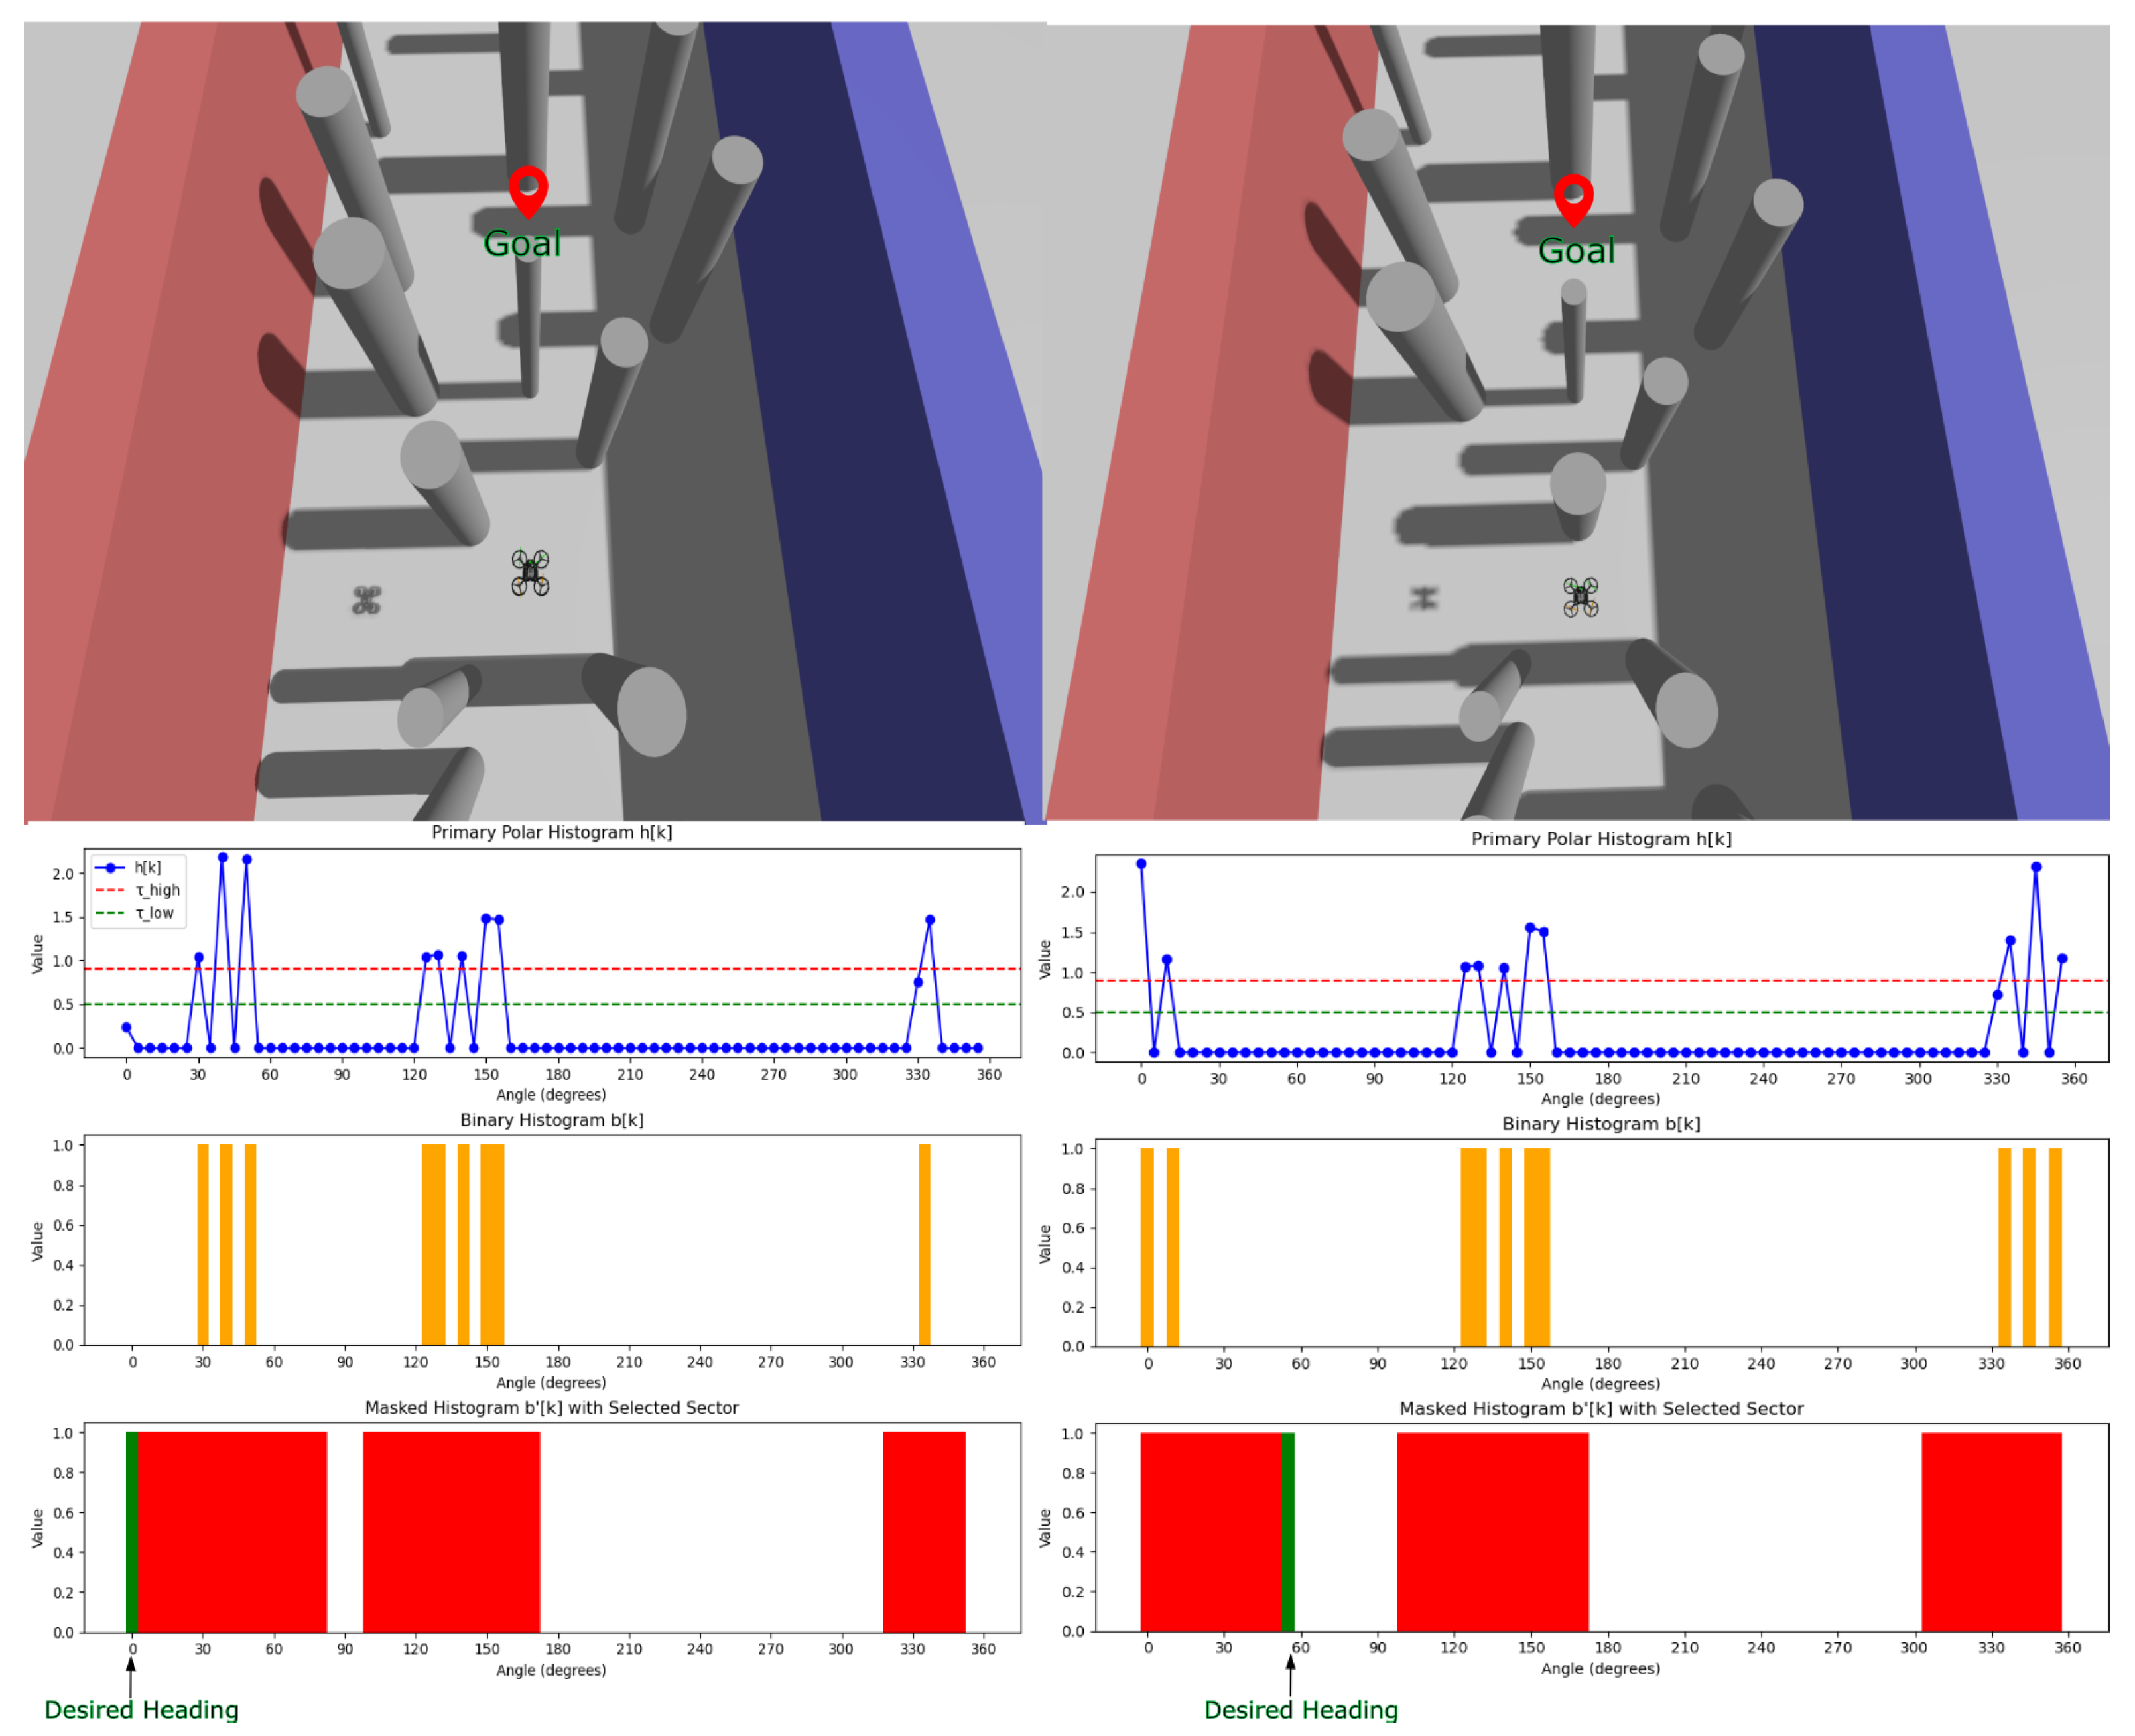
3.3. Collision Avoidance
| Algorithm 1: Obstacle-Aware Sector Selection Using VFH+ |
 |
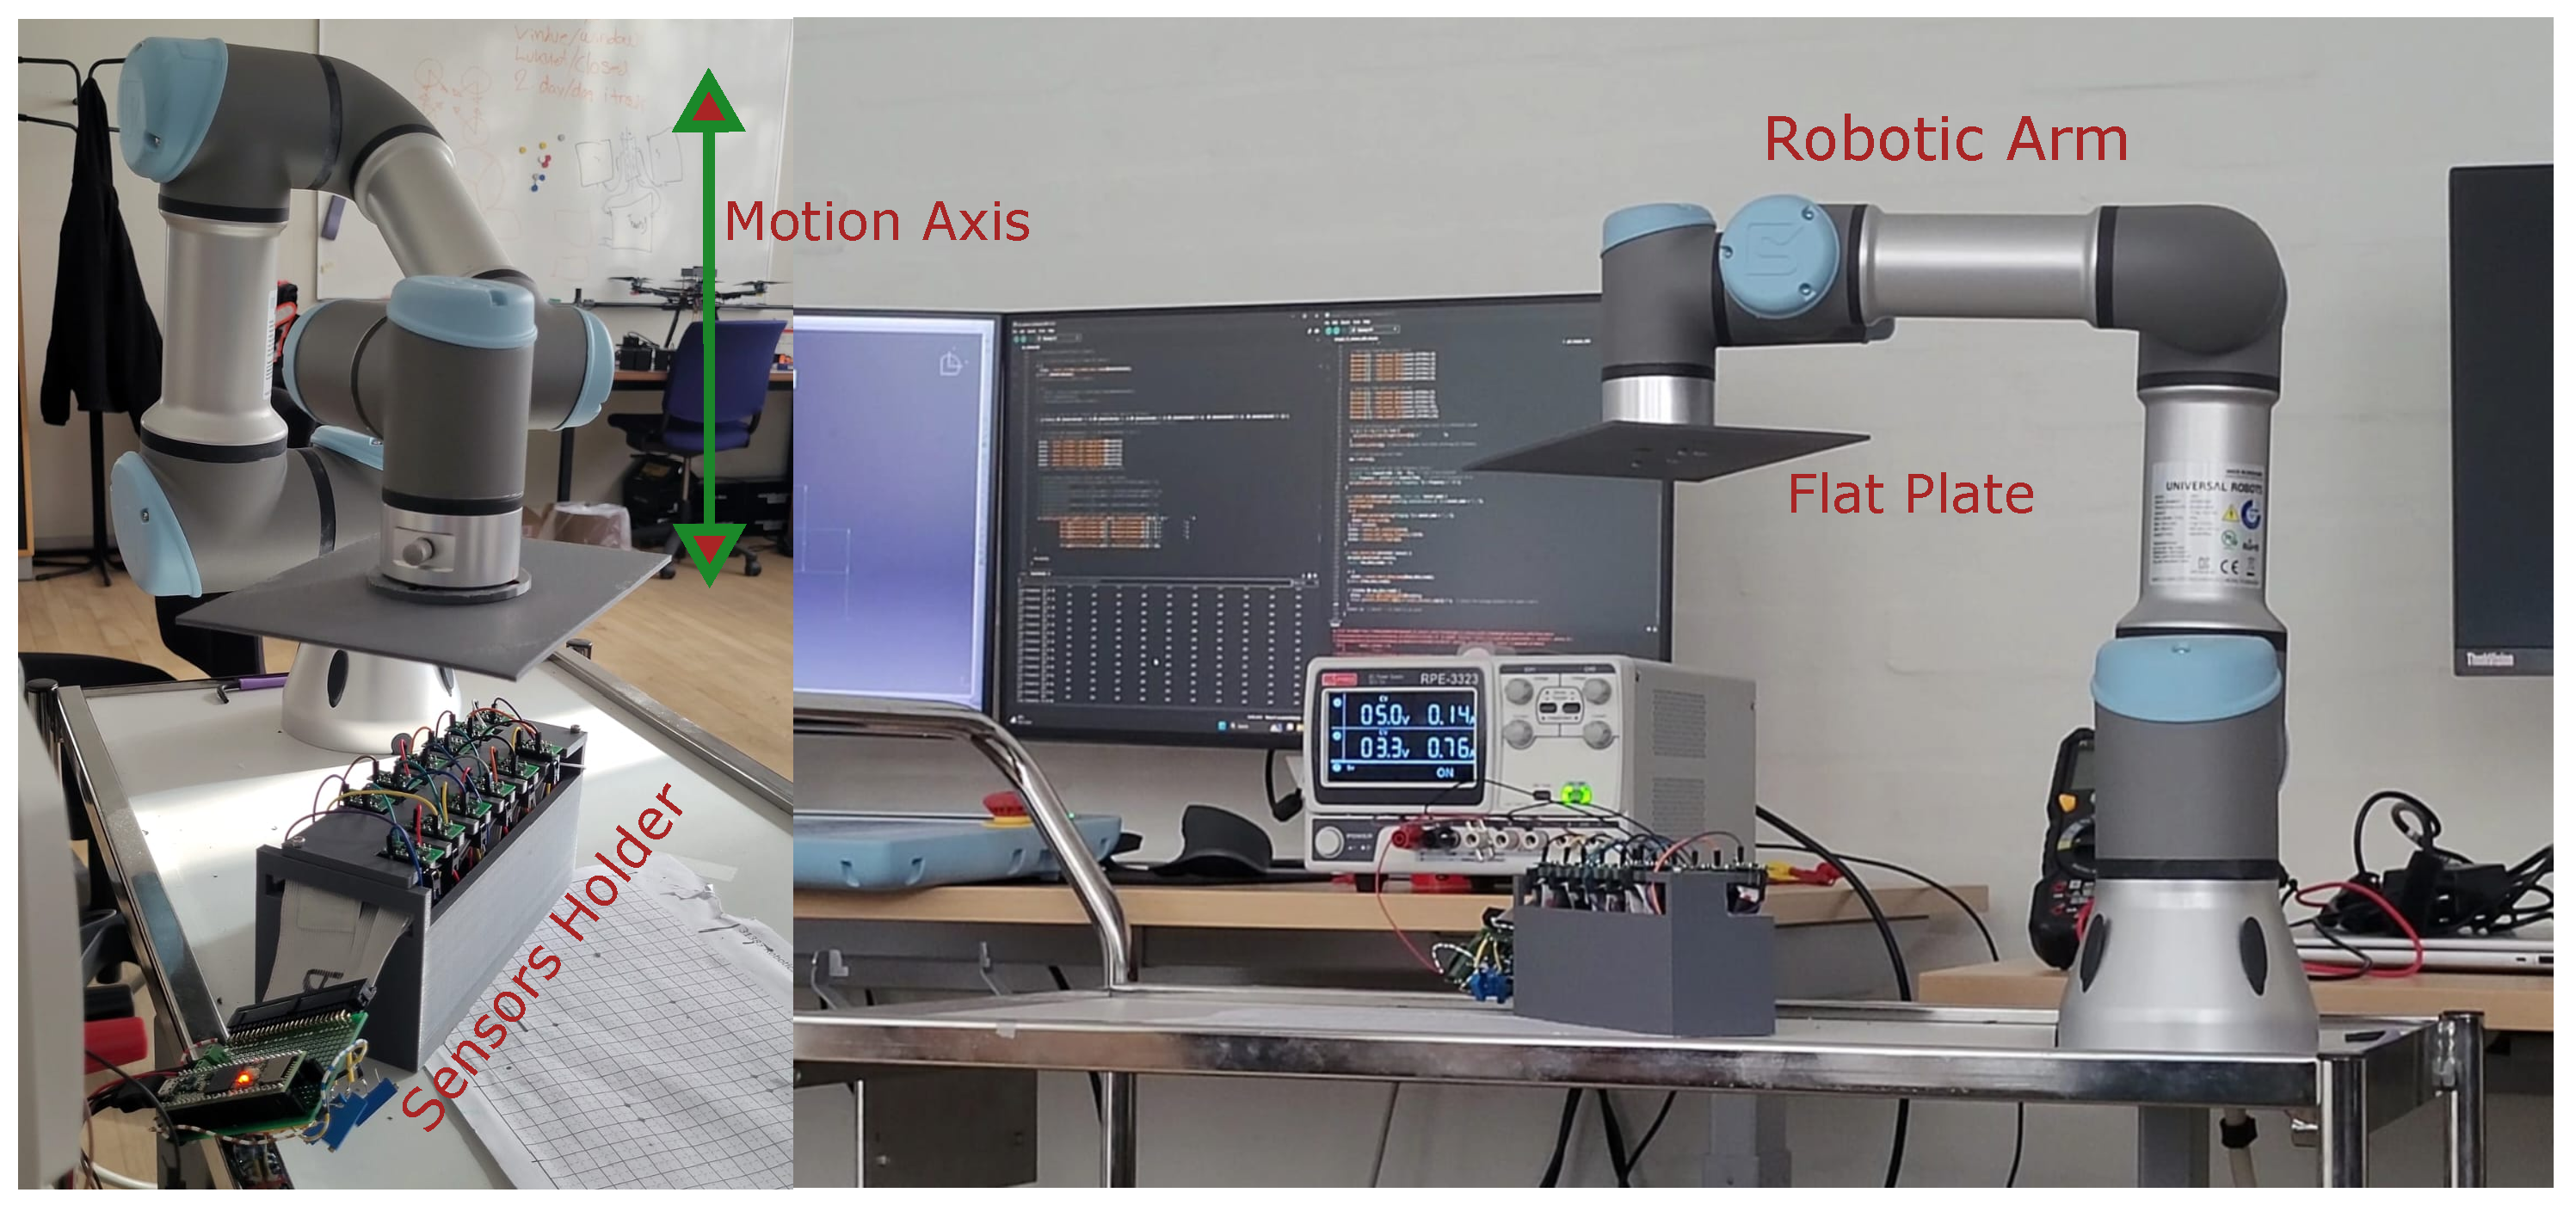
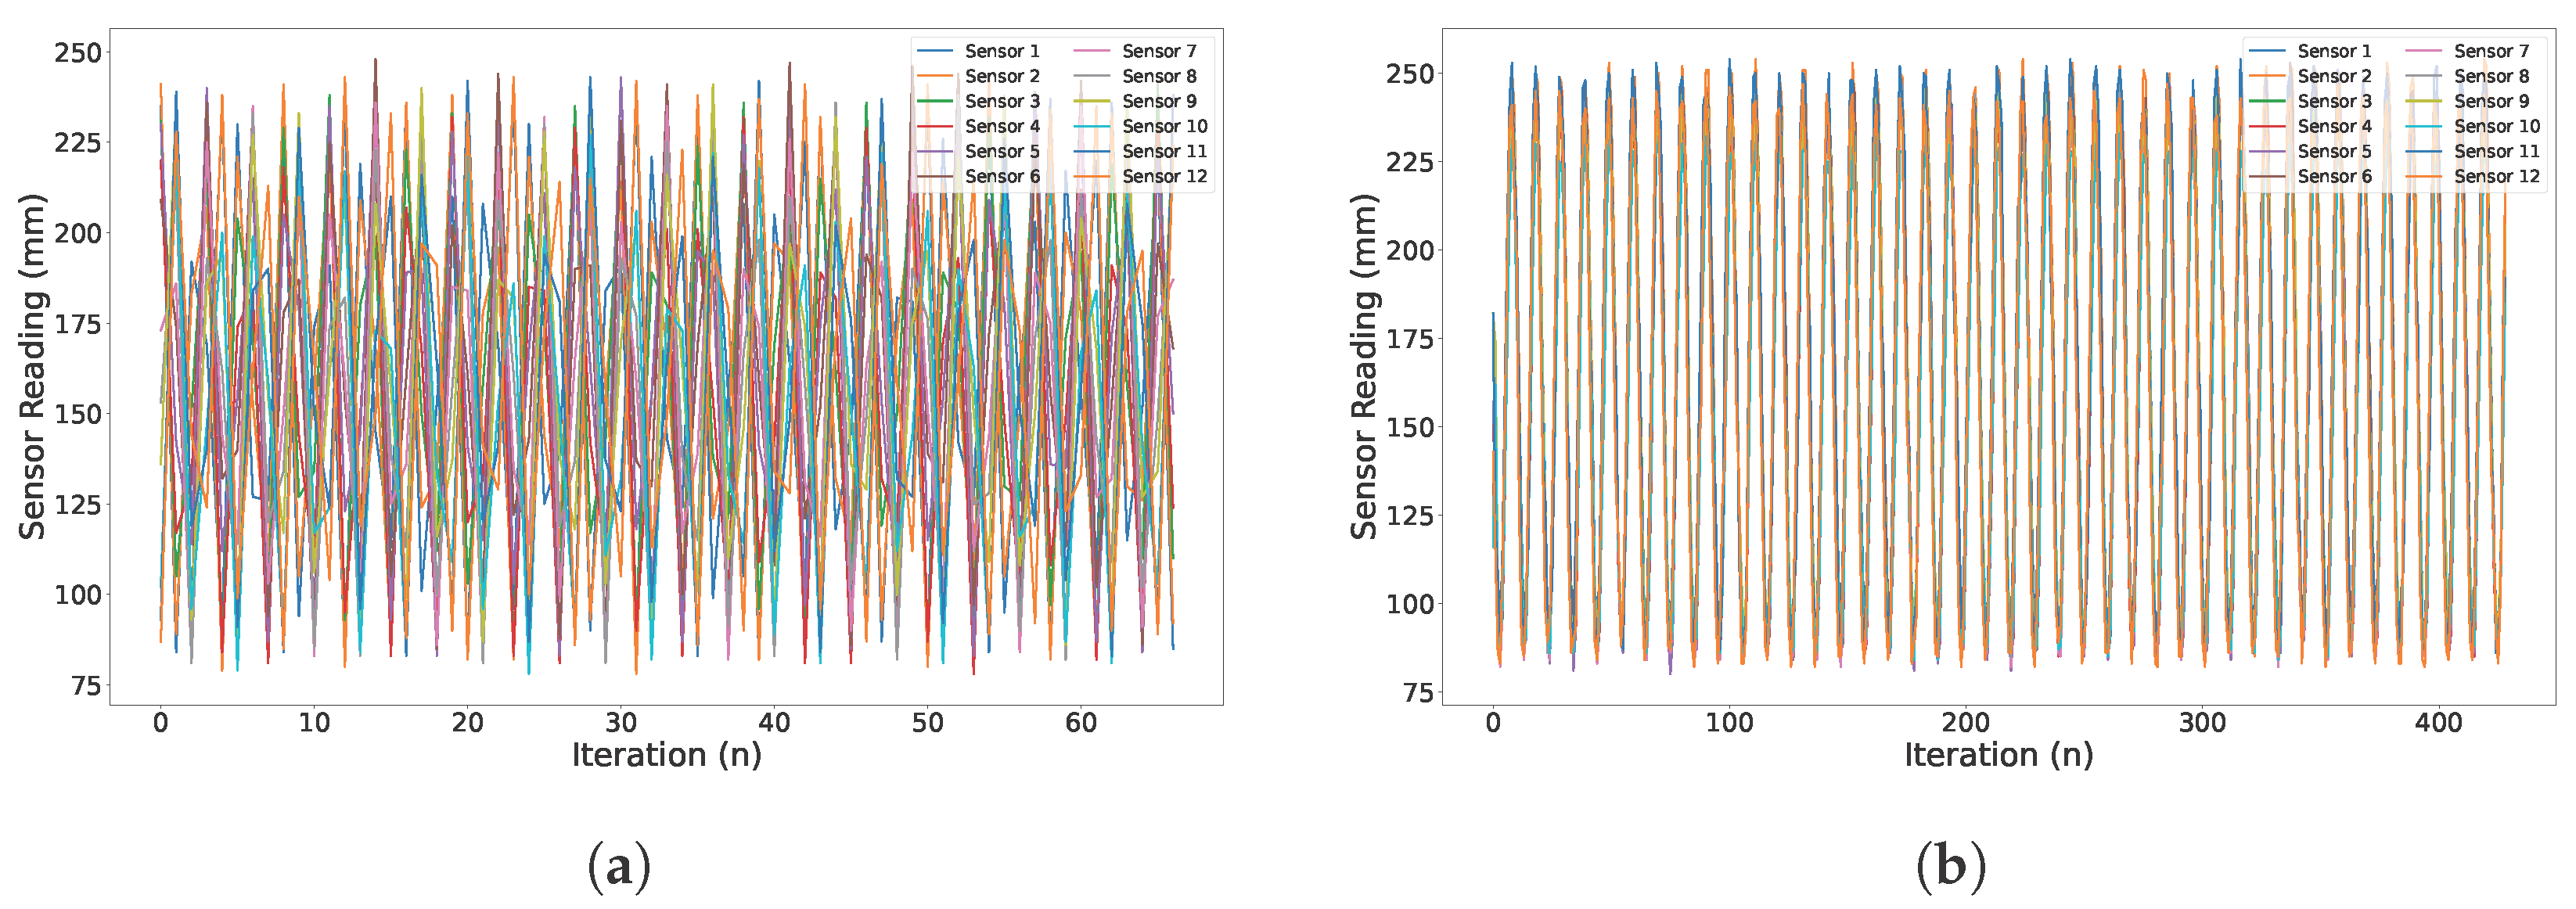
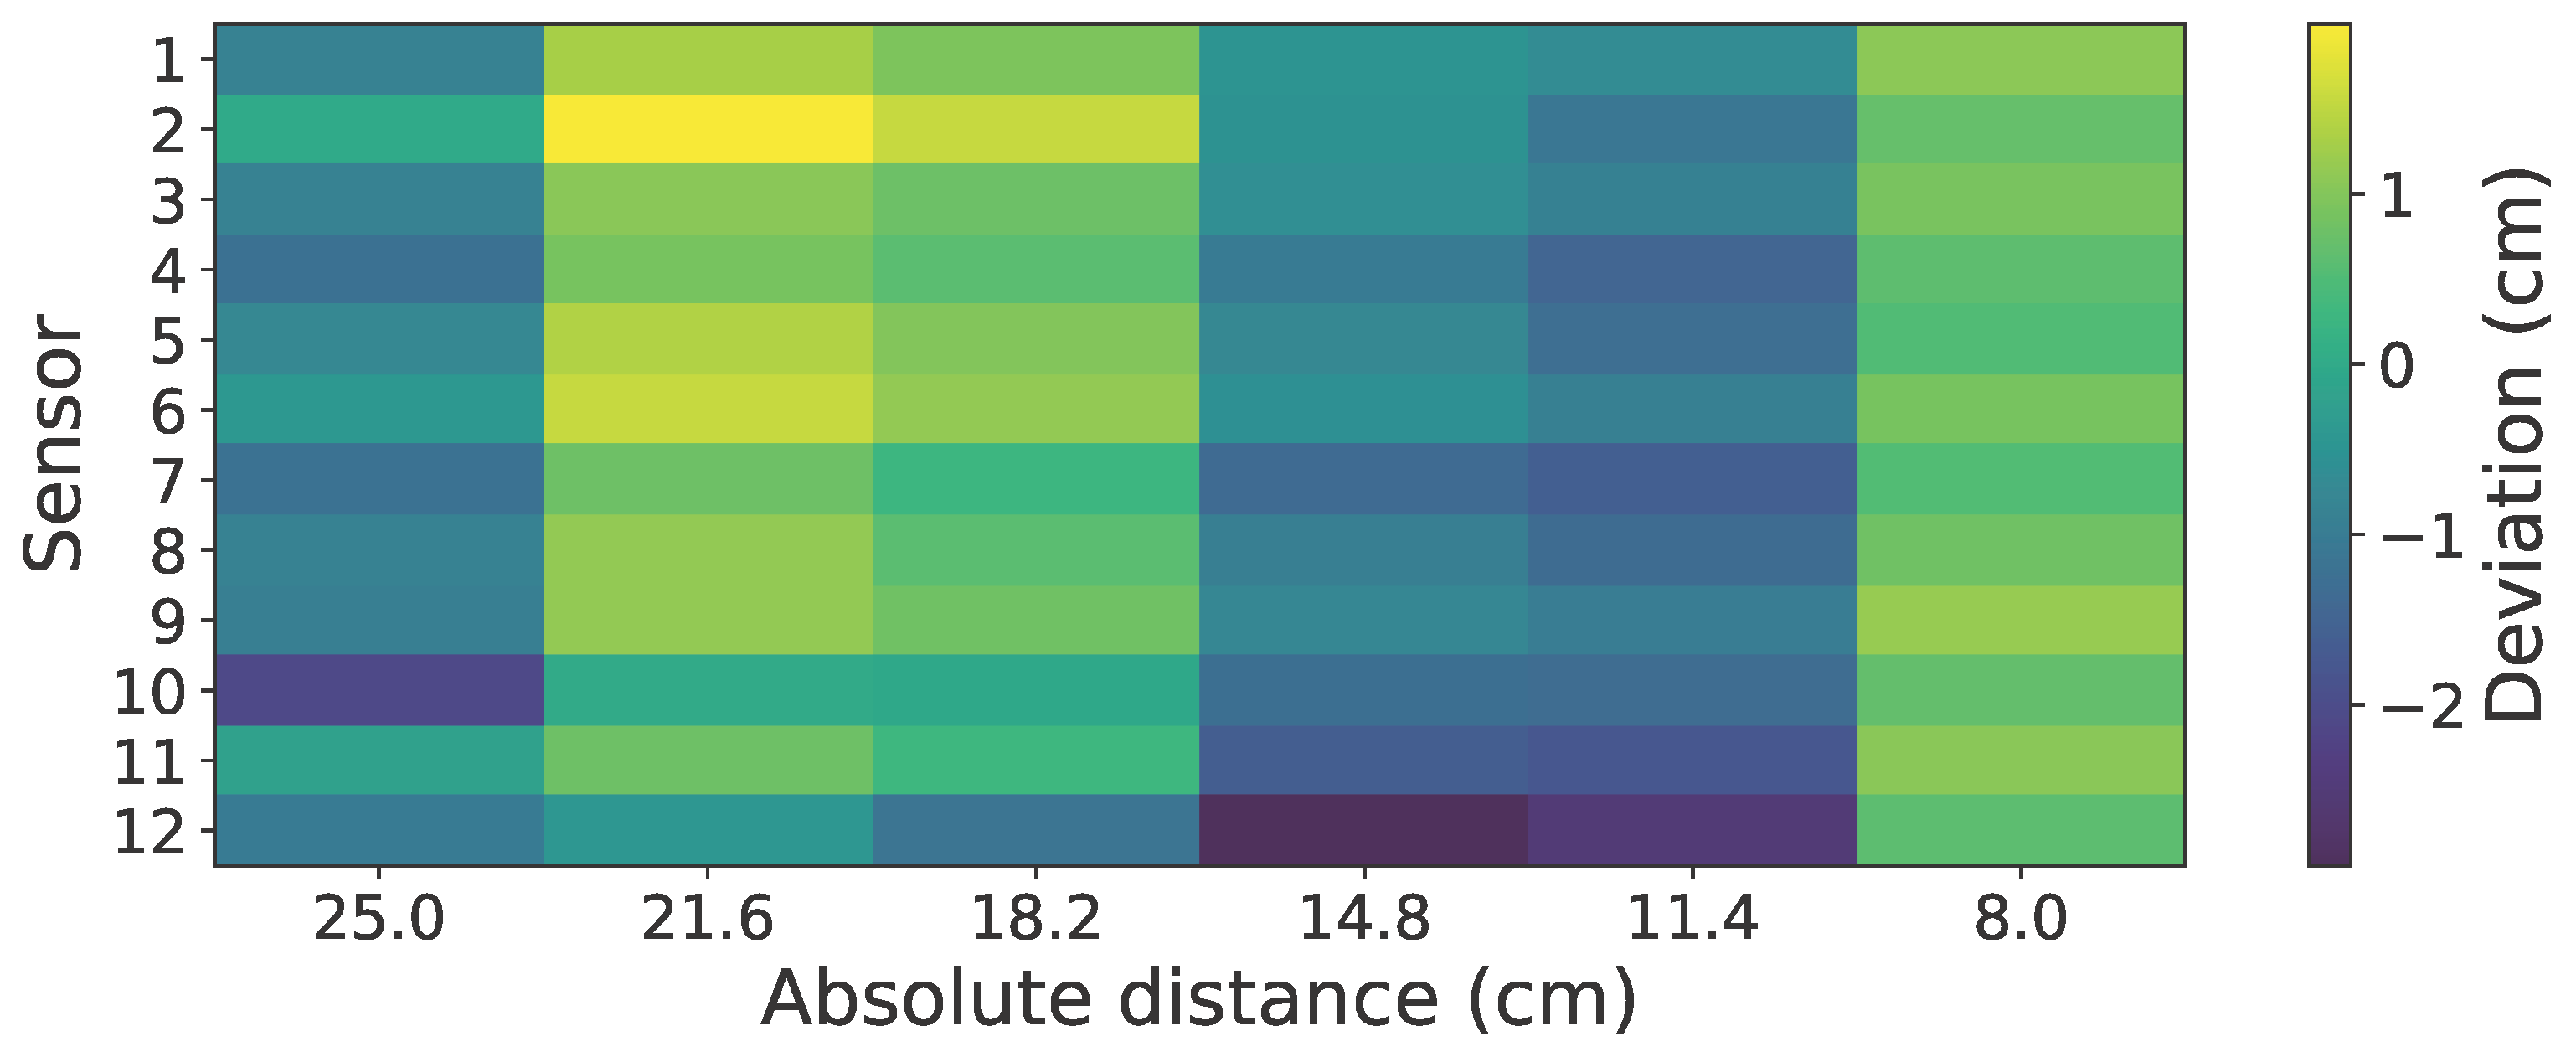
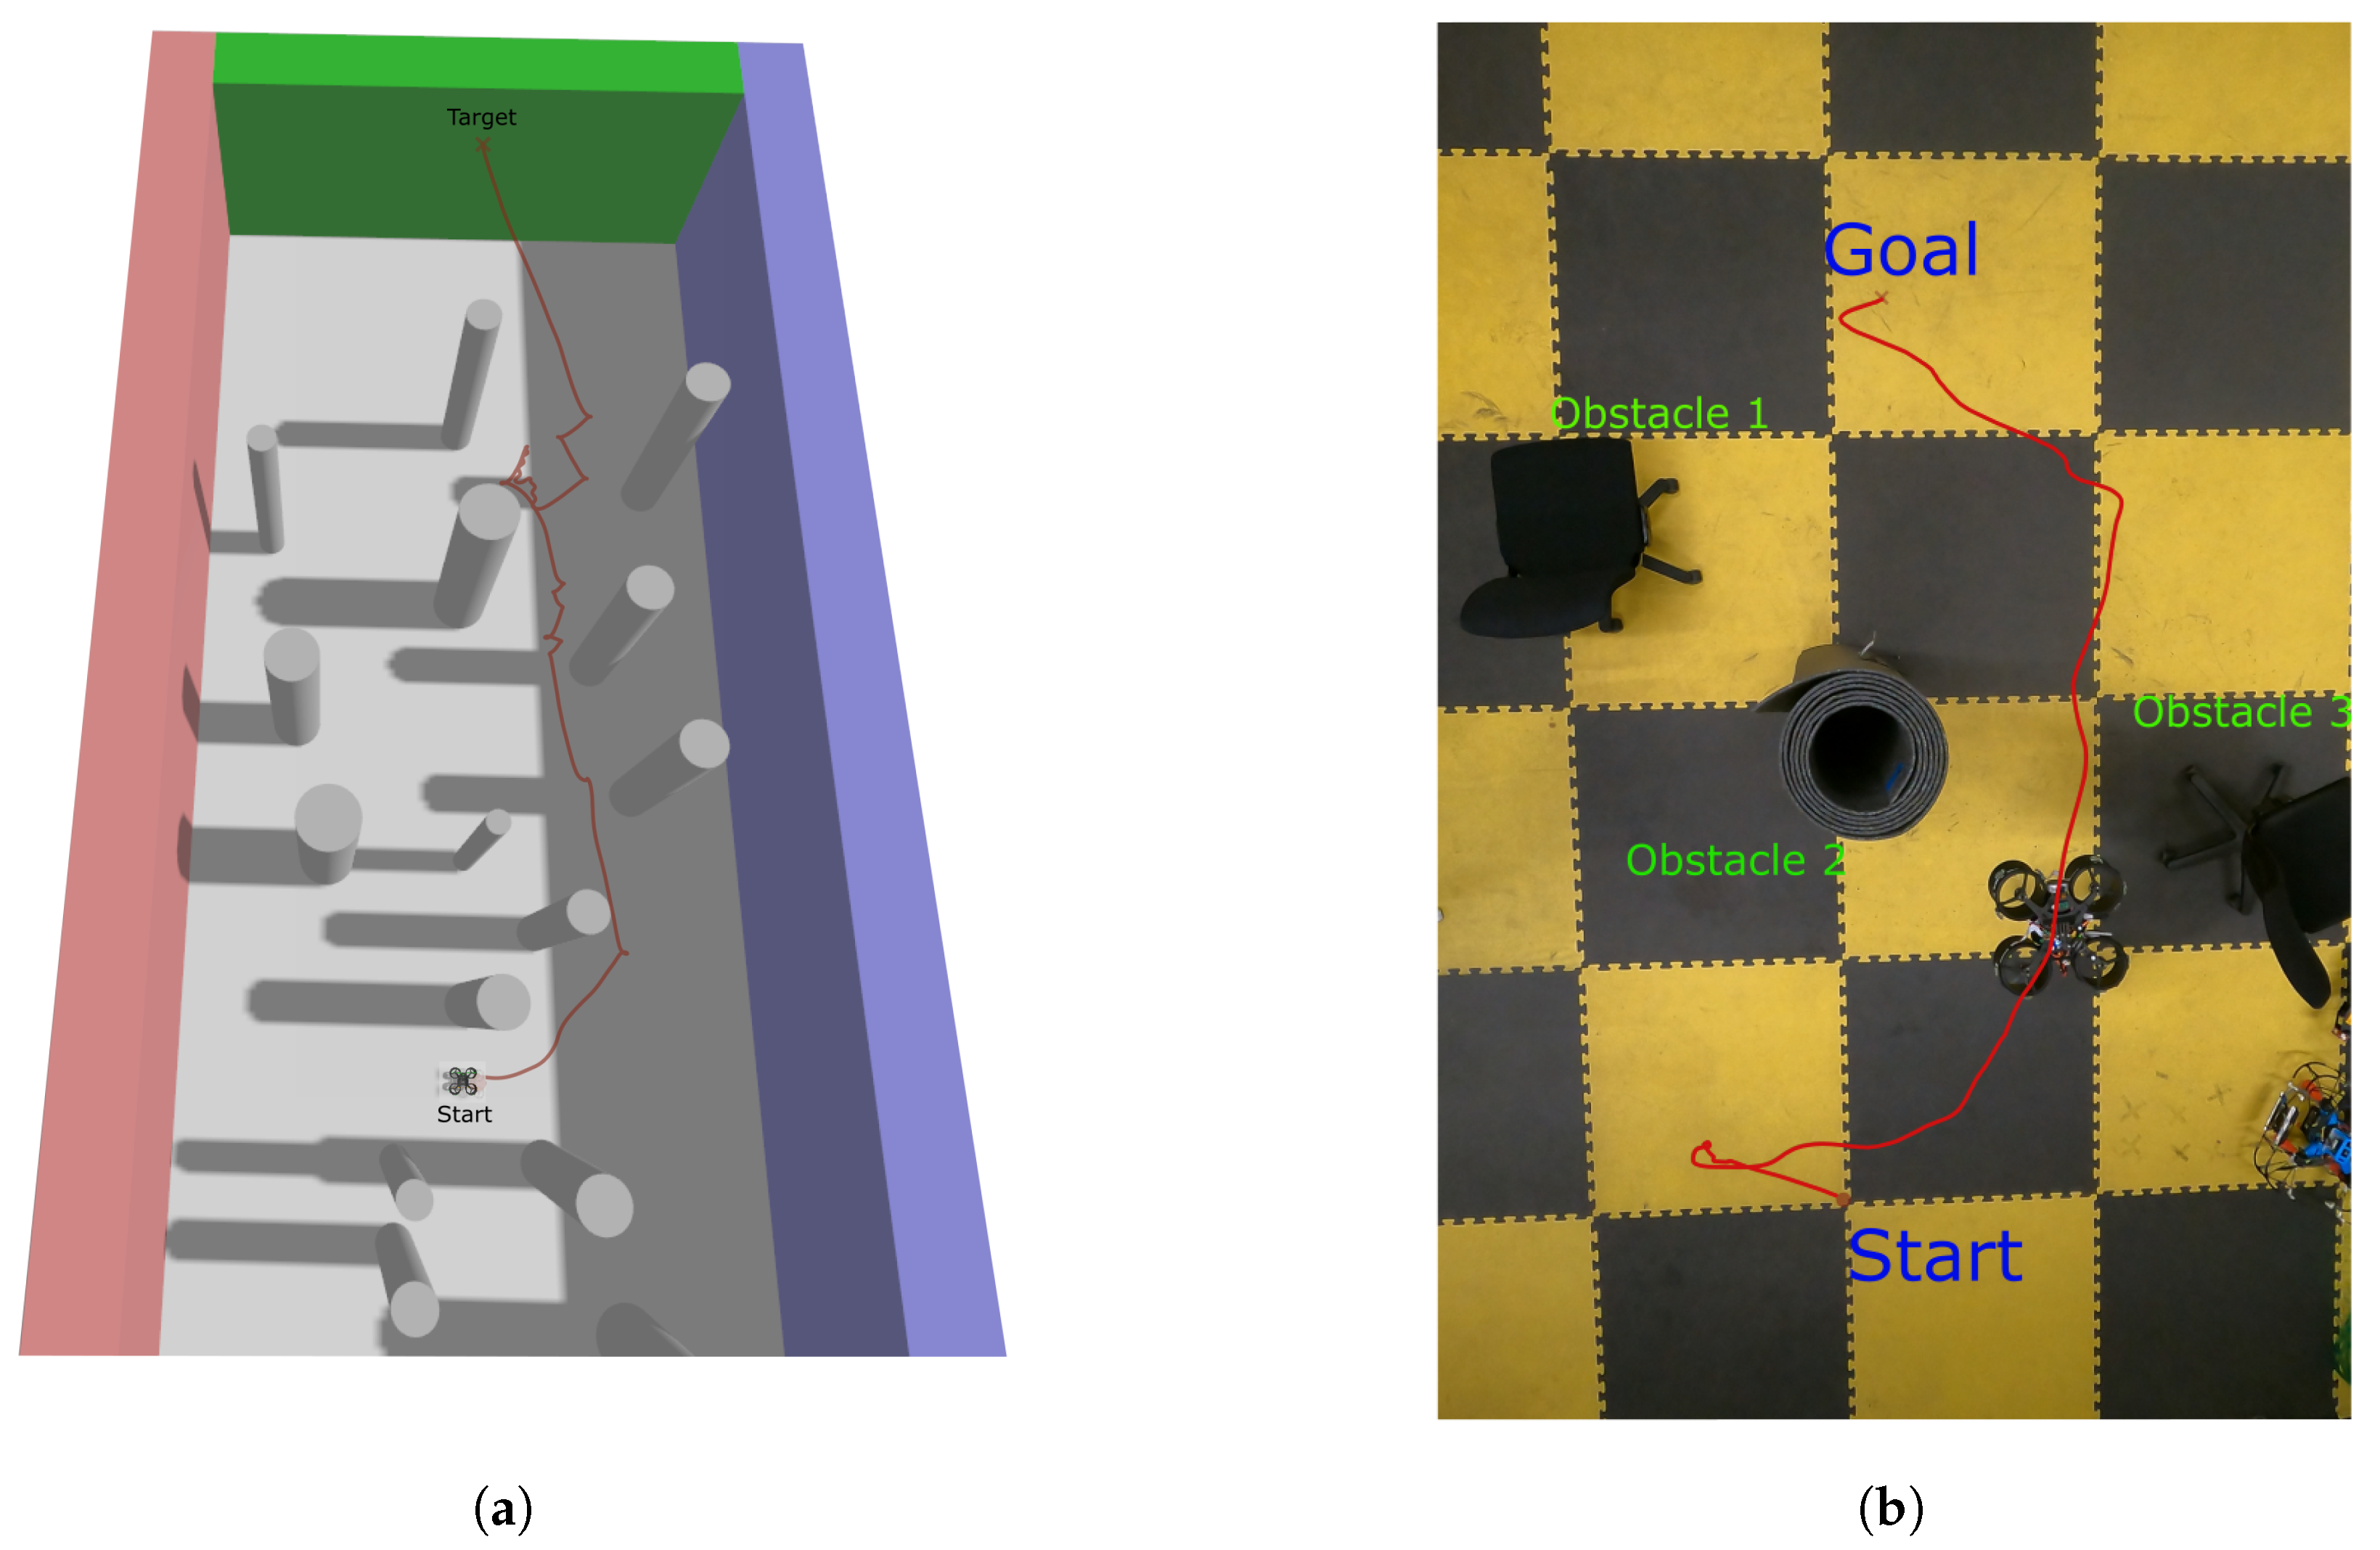
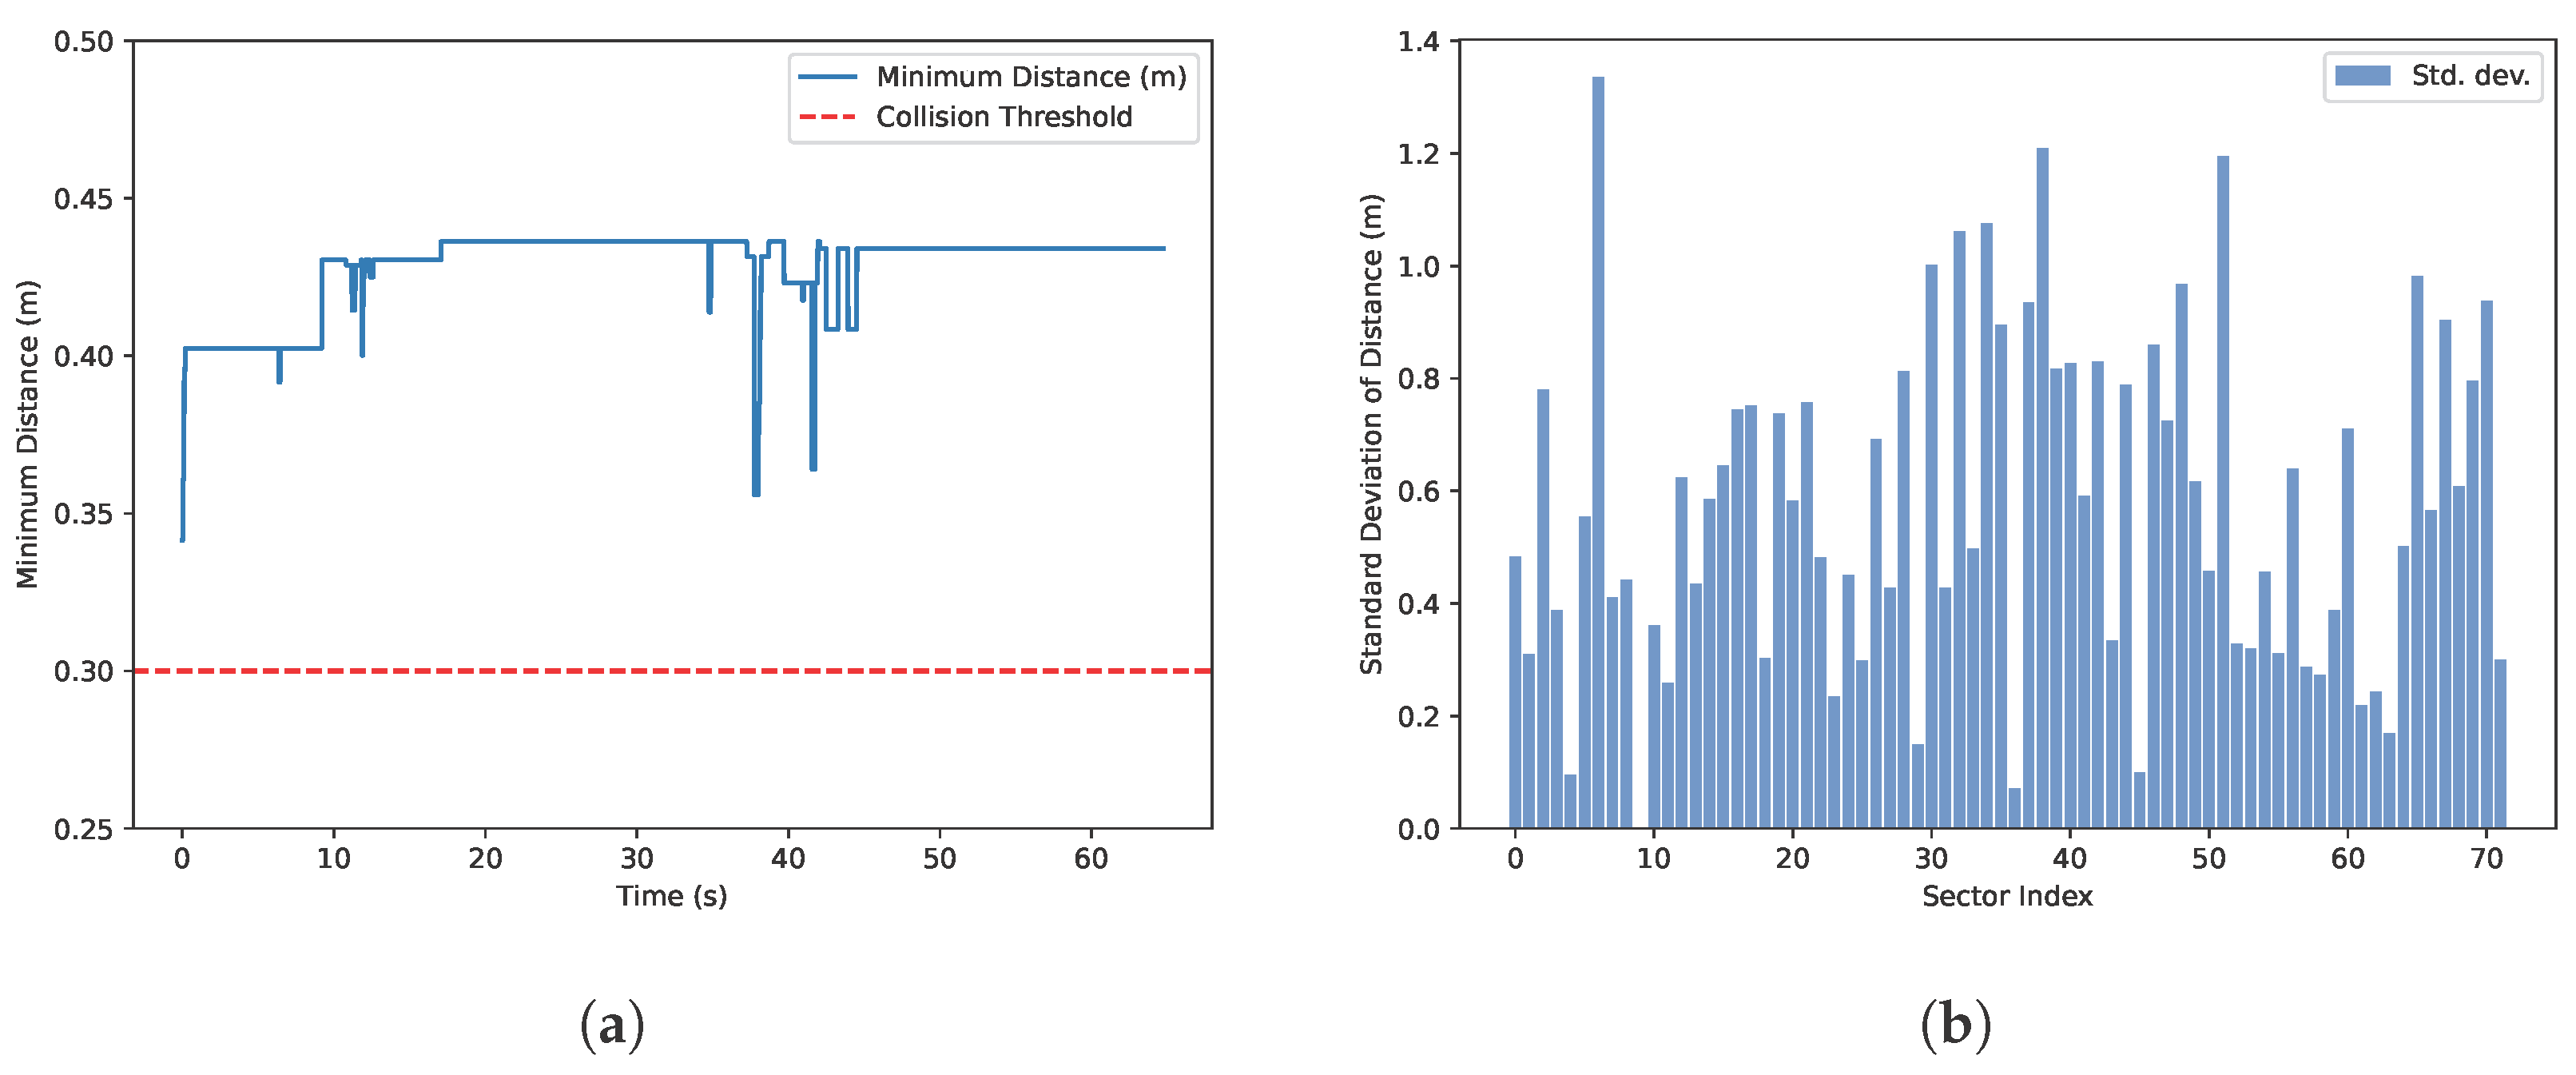
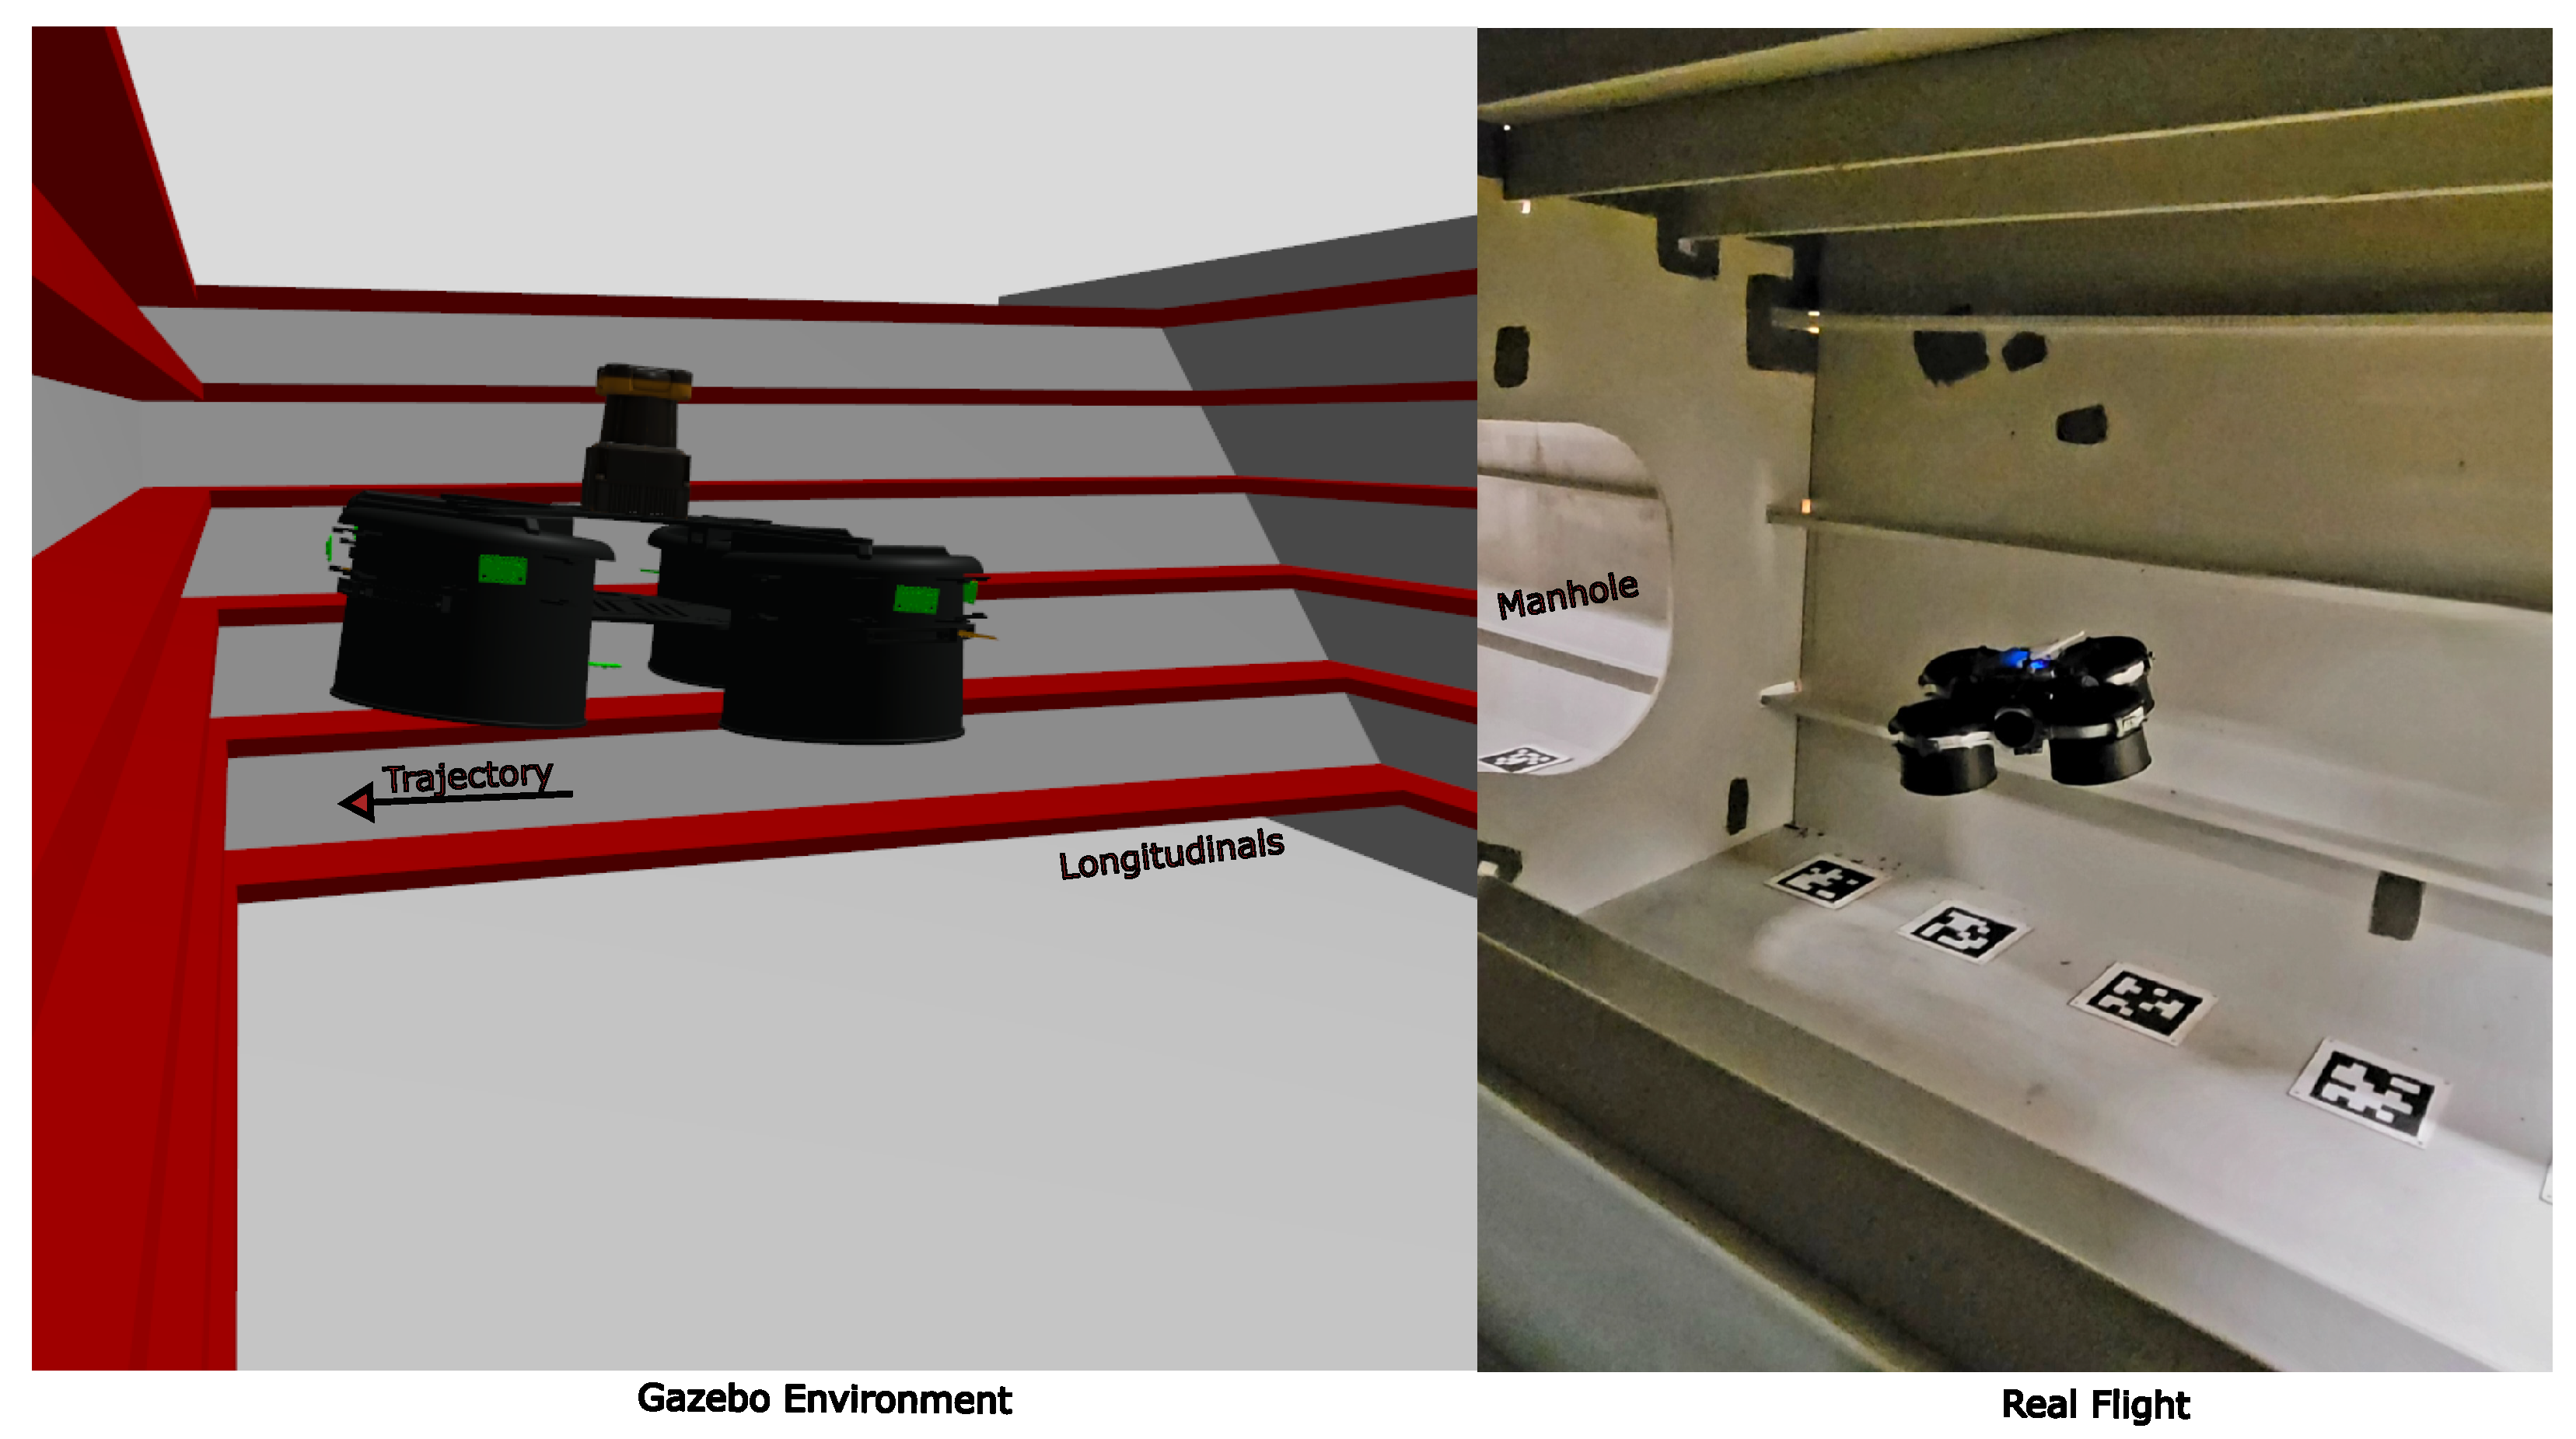
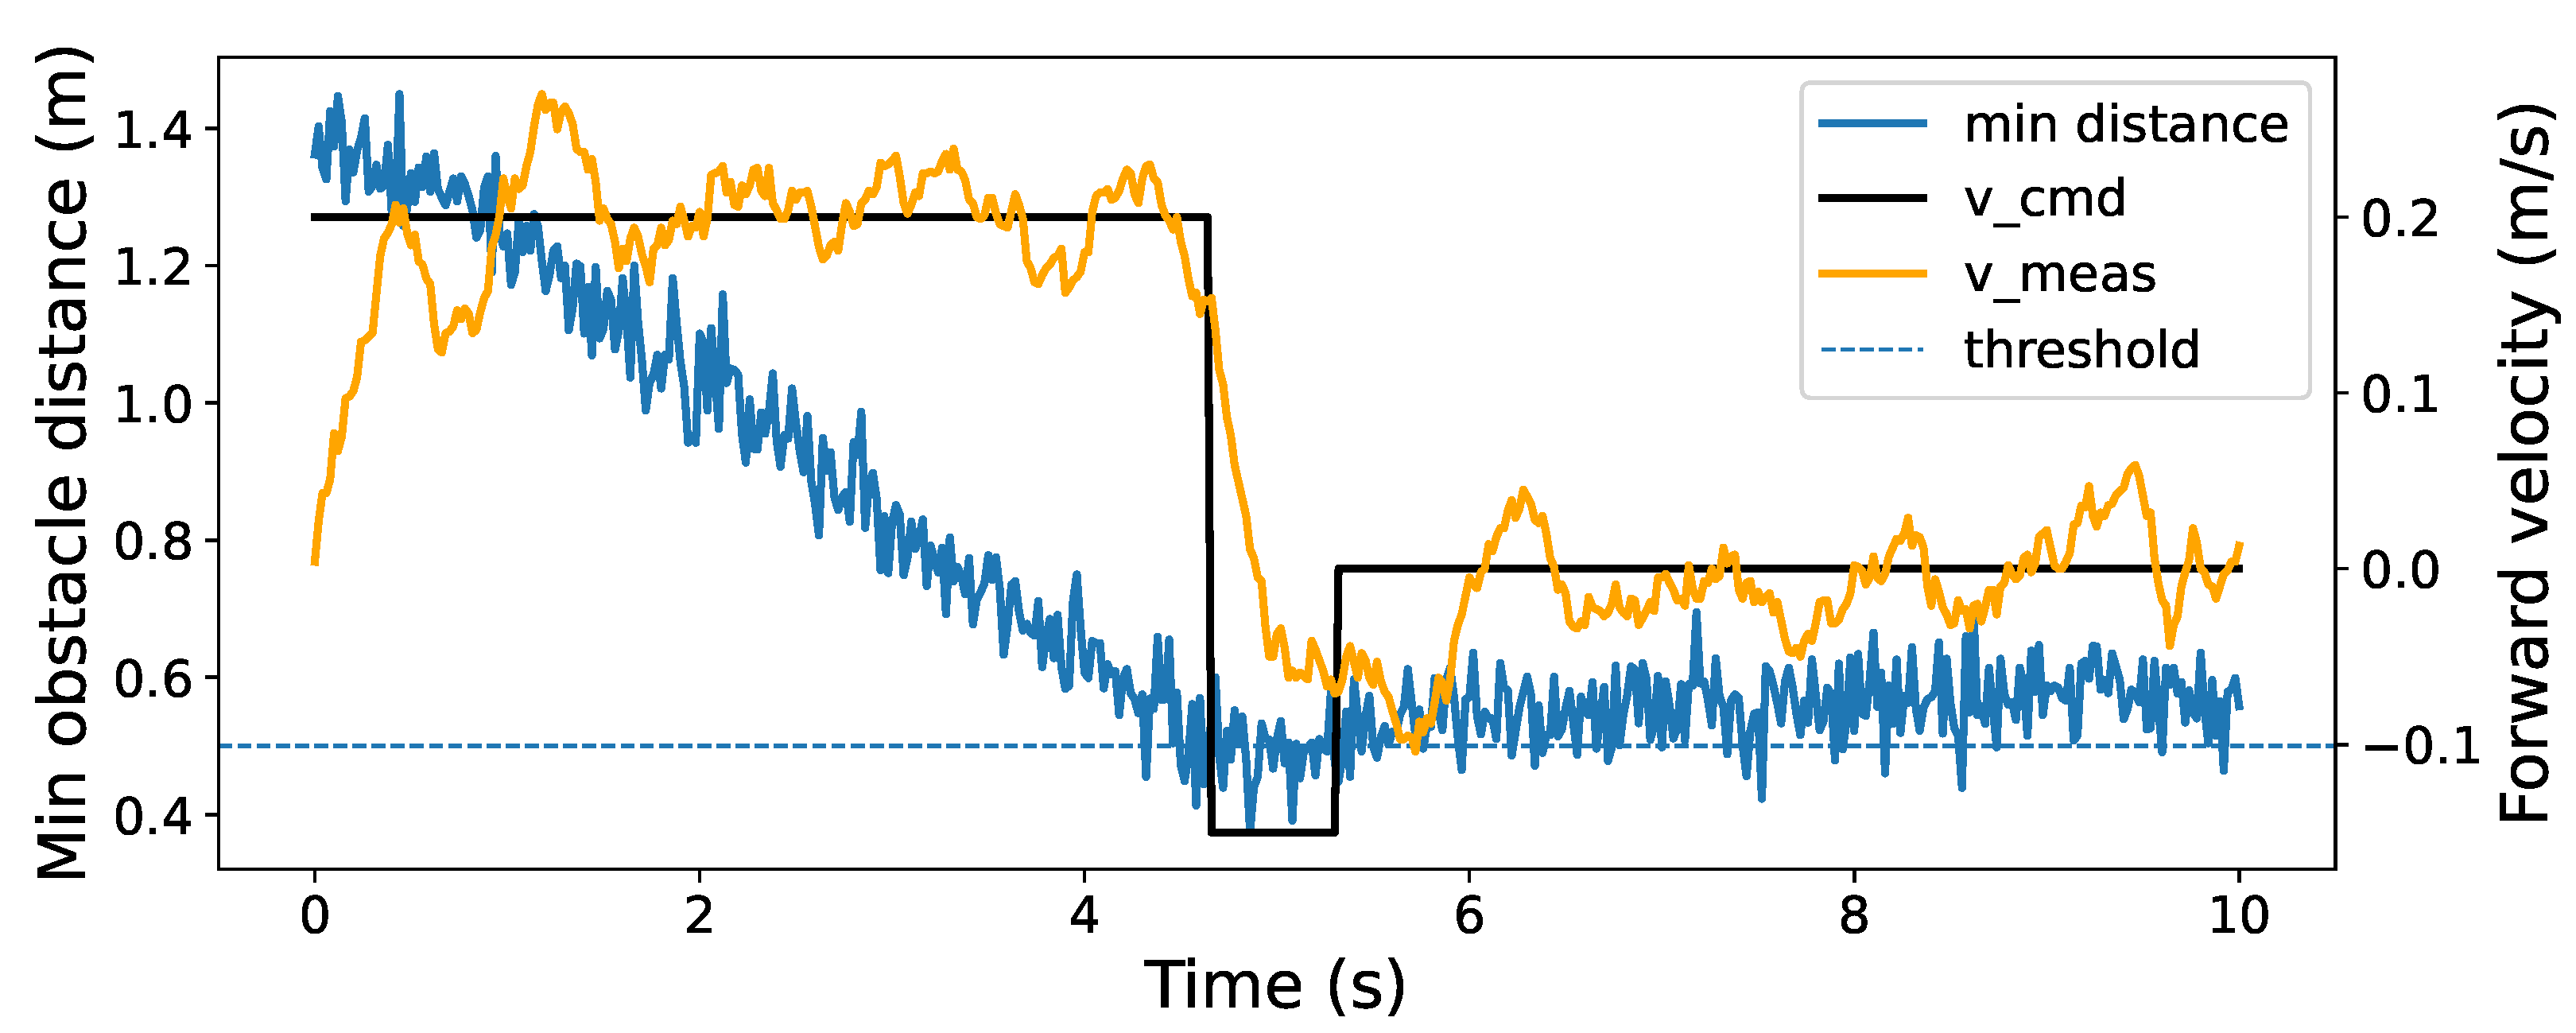
4. Simulation and Experimental Validation
5. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Melnyk, O.; Onyshchenko, S.; Onishchenko, O.; Koskina, Y.; Lohinov, O.; Veretennik, O.; Stukalenko, O. Fundamental concepts of deck cargo handling and transportation safety. Eur. Transp. 2024, 98, 1–18. [Google Scholar] [CrossRef] [Scilit]
- Fang, Z.; Yang, S.; Jain, S.; Dubey, G.; Roth, S.; Maeta, S.; Nuske, S.; Zhang, Y.; Scherer, S. Robust autonomous flight in constrained and visually degraded shipboard environments. J. Field Robot. 2017, 34, 25–52. [Google Scholar] [CrossRef] [Scilit]
- Özaslan, T.; Mohta, K.; Keller, J.; Mulgaonkar, Y.; Taylor, C.J.; Kumar, V.; Wozencraft, J.M.; Hood, T. Towards fully autonomous visual inspection of dark featureless dam penstocks using MAVs. In Proceedings of the 2016 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Daejeon, Republic of Korea, 9–14 October 2016; pp. 4998–5005. [Google Scholar]
- Chowdhary, G.; Johnson, E.N.; Magree, D.; Wu, A.; Shein, A. GPS-denied indoor and outdoor monocular vision aided navigation and control of unmanned aircraft. J. Field Robot. 2013, 30, 415–438. [Google Scholar] [CrossRef] [Scilit]
- Brogaard, R.Y.; Hewitt, R.A.; Etter, S.; Kalantari, A.; Boukas, E. Absolute Localization in Feature-Poor Industrial Confined Spaces. In Proceedings of the 2023 IEEE International Symposium on Safety, Security, and Rescue Robotics (SSRR), Fukushima, Japan, 13–15 November 2023; pp. 69–75. [Google Scholar]
- Andersen, R.E.; Brogaard, R.Y.; Boukas, E. Remote Inspection Techniques: A review of autonomous robotic inspection for marine vessels. IEEE Trans. Field Robot. 2024, 2, 1–20. [Google Scholar] [CrossRef] [Scilit]
- Brogaard, R.Y.; Zajaczkowski, M.; Kovac, L.; Ravn, O.; Boukas, E. Towards uav-based absolute hierarchical localization in confined spaces. In Proceedings of the 2020 IEEE International Symposium on Safety, Security, and Rescue Robotics (SSRR), Abu Dhabi, United Arab Emirates, 4–6 November 2020; pp. 182–188. [Google Scholar]
- Brogaard, R.Y.; Andersen, R.E.; Kovac, L.; Zajaczkowski, M.; Boukas, E. Towards an autonomous, visual inspection-aware 3d exploration and mapping system for water ballast tanks of marine vessels. In Proceedings of the 2021 IEEE International Conference on Imaging Systems and Techniques (IST), Virtual, 24–26 August 2021; pp. 1–6. [Google Scholar]
- Sanfourche, M.; Delaune, J.; Le Besnerais, G.; De Plinval, H.; Israel, J.; Cornic, P.; Treil, A.; Watanabe, Y.; Plyer, A. Perception for UAV: Vision-Based Navigation and Environment Modeling. Aerosp. Lab 2012, 4, 1–19. [Google Scholar]
- Macario Barros, A.; Michel, M.; Moline, Y.; Corre, G.; Carrel, F. A comprehensive survey of visual slam algorithms. Robotics 2022, 11, 24. [Google Scholar] [CrossRef] [Scilit]
- Brogaard, R.Y.; Ravn, O.; Boukas, E. Gpu-accelerated localization in confined spaces using deep geometric features. In Proceedings of the 2021 IEEE International Conference on Imaging Systems and Techniques (IST), Virtual, 24–26 August 2021; pp. 1–6. [Google Scholar]
- Kumar, G.A.; Patil, A.K.; Patil, R.; Park, S.S.; Chai, Y.H. A LiDAR and IMU integrated indoor navigation system for UAVs and its application in real-time pipeline classification. Sensors 2017, 17, 1268. [Google Scholar] [CrossRef] [Scilit]
- Elhousni, M.; Huang, X. A survey on 3d lidar localization for autonomous vehicles. In Proceedings of the 2020 IEEE Intelligent Vehicles Symposium (IV), Las Vegas, NV, USA, 19 October–13 November 2020; pp. 1879–1884. [Google Scholar]
- Mueller, T.J.; Jansen, B.J., Jr. Aerodynamic measurements at low Reynolds numbers. In Proceedings of the 12th Aerodynamic Testing Conference, Williamsburg, VA, USA, 22–24 March 1982; p. 598. [Google Scholar]
- Zhao, H. Development of a Dynamic Model of a Ducted Fan VTOL UAV. Ph.D. Thesis, RMIT University, Melbourne, Australia, 2009. [Google Scholar]
- Pereira, J.L. Hover and Wind-Tunnel Testing of Shrouded Rotors for Improved Micro Air Vehicle Design; University of Maryland: College Park, MD, USA, 2008. [Google Scholar]
- Powers, C.; Mellinger, D.; Kushleyev, A.; Kothmann, B.; Kumar, V. Influence of aerodynamics and proximity effects in quadrotor flight. In Proceedings of the Experimental Robotics: The 13th International Symposium on Experimental Robotics; Springer: Berlin/Heidelberg, Germany, 2013; pp. 289–302. [Google Scholar]
- Jain, K.P.; Fortmuller, T.; Byun, J.; Mäkiharju, S.A.; Mueller, M.W. Modeling of aerodynamic disturbances for proximity flight of multirotors. In Proceedings of the 2019 International Conference on Unmanned Aircraft Systems (ICUAS), Atlanta, GA, USA, 11–14 June 2019; pp. 1261–1269. [Google Scholar]
- Sanchez-Cuevas, P.; Heredia, G.; Ollero, A. Characterization of the aerodynamic ground effect and its influence in multirotor control. Int. J. Aerosp. Eng. 2017, 2017, 1823056. [Google Scholar] [CrossRef] [Scilit]
- Sanchez-Cuevas, P.J.; Heredia, G.; Ollero, A. Multirotor UAS for bridge inspection by contact using the ceiling effect. In Proceedings of the 2017 International Conference on Unmanned Aircraft Systems (ICUAS), Miami, FL, USA, 13–16 June 2017; pp. 767–774. [Google Scholar]
- Stremousov, K.; Arkhipov, M.; Serokhvostov, S. Small height duct design for multicopter fan. In Proceedings of the 30th Congress of the International Council of the Aeronautical Sciences, ICAS 2016, Daejeon, Republic of Korea, 25–30 September 2016. [Google Scholar]
- Vilaça, J.; Vale, A.; Cunha, F. Design optimization of a ducted-drone to perform inspection operations. In Proceedings of the Robot 2019: Fourth Iberian Robotics Conference: Advances in Robotics, Volume 1; Springer: Berlin/Heidelberg, Germany, 2020; pp. 3–15. [Google Scholar]
- Cai, H.; Zhang, Z.; Deng, S. Numerical prediction of unsteady aerodynamics of a ducted fan unmanned aerial vehicle in hovering. Aerospace 2022, 9, 318. [Google Scholar] [CrossRef] [Scilit]
- Moffatt, A.; Platt, E.; Mondragon, B.; Kwok, A.; Uryeu, D.; Bhandari, S. Obstacle detection and avoidance system for small UAVs using a LiDAR. In Proceedings of the 2020 International Conference on Unmanned Aircraft Systems (ICUAS), Athens, Greece, 1–4 September 2020; pp. 633–640. [Google Scholar]
- Gadde, C.S.; Gadde, M.S.; Mohanty, N.; Sundaram, S. Fast obstacle avoidance motion in small quadcopter operation in a cluttered environment. In Proceedings of the 2021 IEEE International Conference on Electronics, Computing and Communication Technologies (CONECCT), Bangalore, India, 9–11 July 2021; pp. 1–6. [Google Scholar]
- Bareiss, D.; Bourne, J.R.; Leang, K.K. On-board model-based automatic collision avoidance: Application in remotely-piloted unmanned aerial vehicles. Auton. Robot. 2017, 41, 1539–1554. [Google Scholar] [CrossRef] [Scilit]
- Yu, H.; Zhang, F.; Huang, P.; Wang, C.; Yuanhao, L. Autonomous obstacle avoidance for uav based on fusion of radar and monocular camera. In Proceedings of the 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, NV, USA, 25–29 October 2020; pp. 5954–5961. [Google Scholar]
- Miccinesi, L.; Bigazzi, L.; Consumi, T.; Pieraccini, M.; Beni, A.; Boni, E.; Basso, M. Geo-referenced mapping through an anti-collision radar aboard an unmanned aerial system. Drones 2022, 6, 72. [Google Scholar] [CrossRef] [Scilit]
- Gageik, N.; Benz, P.; Montenegro, S. Obstacle detection and collision avoidance for a UAV with complementary low-cost sensors. IEEE Access 2015, 3, 599–609. [Google Scholar] [CrossRef] [Scilit]
- Yang, L.; Feng, X.; Zhang, J.; Shu, X. Multi-ray modeling of ultrasonic sensors and application for micro-UAV localization in indoor environments. Sensors 2019, 19, 1770. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Singla, A.; Padakandla, S.; Bhatnagar, S. Memory-based deep reinforcement learning for obstacle avoidance in UAV with limited environment knowledge. IEEE Trans. Intell. Transp. Syst. 2019, 22, 107–118. [Google Scholar] [CrossRef]
- Hrabar, S. An evaluation of stereo and laser-based range sensing for rotorcraft unmanned aerial vehicle obstacle avoidance. J. Field Robot. 2012, 29, 215–239. [Google Scholar] [CrossRef] [Scilit]
- Iacono, M.; Sgorbissa, A. Path following and obstacle avoidance for an autonomous UAV using a depth camera. Robot. Auton. Syst. 2018, 106, 38–46. [Google Scholar] [CrossRef] [Scilit]
- Zahran, S.; Moussa, A.M.; Sesay, A.B.; El-Sheimy, N. A new velocity meter based on Hall effect sensors for UAV indoor navigation. IEEE Sens. J. 2018, 19, 3067–3076. [Google Scholar] [CrossRef] [Scilit]
- Chen, D.; Gao, G.X. Probabilistic graphical fusion of LiDAR, GPS, and 3D building maps for urban UAV navigation. Navigation 2019, 66, 151–168. [Google Scholar] [CrossRef] [Scilit]
- Liao, F.; Lai, S.; Hu, Y.; Cui, J.; Wang, J.L.; Teo, R.; Lin, F. 3D motion planning for UAVs in GPS-denied unknown forest environment. In Proceedings of the 2016 IEEE Intelligent Vehicles Symposium (IV), Gotenburg, Sweden, 19–22 June 2016; pp. 246–251. [Google Scholar]
- Unicomb, J.; Dantanarayana, L.; Arukgoda, J.; Ranasinghe, R.; Dissanayake, G.; Furukawa, T. Distance function based 6dof localization for unmanned aerial vehicles in gps denied environments. In Proceedings of the 2017 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Vancouver, BC, Canada, 24–28 September 2017; pp. 5292–5297. [Google Scholar]
- Bi, Y.; Lan, M.; Li, J.; Zhang, K.; Qin, H.; Lai, S.; Chen, B.M. Robust autonomous flight and mission management for mavs in gps-denied environments. In Proceedings of the 2017 11th Asian Control Conference (ASCC), Gold Coast, Australia, 17–20 December 2017; pp. 67–72. [Google Scholar]
- Li, Y.; Scanavino, M.; Capello, E.; Dabbene, F.; Guglieri, G.; Vilardi, A. A novel distributed architecture for UAV indoor navigation. Transp. Res. Procedia 2018, 35, 13–22. [Google Scholar] [CrossRef] [Scilit]
- Abah, C.; Orekhov, A.L.; Johnston, G.L.; Yin, P.; Choset, H.; Simaan, N. A multi-modal sensor array for safe human-robot interaction and mapping. In Proceedings of the 2019 International Conference on Robotics and Automation (ICRA), Montreal, QC, Canada, 20–24 May 2019; pp. 3768–3774. [Google Scholar]
- Ding, Y.; Thomas, U. Collision avoidance with proximity servoing for redundant serial robot manipulators. In Proceedings of the 2020 IEEE International Conference on Robotics and Automation (ICRA), Paris, France, 31 May–31 August 2020; pp. 10249–10255. [Google Scholar]
- López, E.; Barea, R.; Gómez, A.; Saltos, Á.; Bergasa, L.M.; Molinos, E.J.; Nemra, A. Indoor SLAM for micro aerial vehicles using visual and laser sensor fusion. In Proceedings of the Robot 2015: Second Iberian Robotics Conference: Advances in Robotics, Volume 1; Springer: Berlin/Heidelberg, Germany, 2015; pp. 531–542. [Google Scholar]
- Mansouri, S.S.; Kanellakis, C.; Kominiak, D.; Nikolakopoulos, G. Deploying MAVs for autonomous navigation in dark underground mine environments. Robot. Auton. Syst. 2020, 126, 103472. [Google Scholar] [CrossRef] [Scilit]
- Quist, E.B.; Niedfeldt, P.C.; Beard, R.W. Radar odometry with recursive-RANSAC. IEEE Trans. Aerosp. Electron. Syst. 2016, 52, 1618–1630. [Google Scholar] [CrossRef] [Scilit]
- Shang, C.; Cheng, L.; Yu, Q.; Wang, X.; Peng, R.; Chen, Y.; Wu, H.; Zhu, Q. Micro aerial vehicle autonomous flight control in tunnel environment. In Proceedings of the 2017 9th International Conference on Modelling, Identification and Control (ICMIC), Kunming, China, 10–12 July 2017; pp. 93–98. [Google Scholar]
- Wei, S.; Dan, G.; Chen, H. Altitude data fusion utilising differential measurement and complementary filter. IET Sci. Meas. Technol. 2016, 10, 874–879. [Google Scholar] [CrossRef] [Scilit]
- Vanegas, F.; Gonzalez, F. Enabling UAV navigation with sensor and environmental uncertainty in cluttered and GPS-denied environments. Sensors 2016, 16, 666. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Sampedro, C.; Rodriguez-Ramos, A.; Bavle, H.; Carrio, A.; De la Puente, P.; Campoy, P. A fully-autonomous aerial robot for search and rescue applications in indoor environments using learning-based techniques. J. Intell. Robot. Syst. 2019, 95, 601–627. [Google Scholar] [CrossRef] [Scilit]
- Yang, N.; Wang, R.; Cremers, D. Feature-based or direct: An evaluation of monocular visual odometry. arXiv 2017, arXiv:1705.04300. [Google Scholar]
- Engel, J.; Schöps, T.; Cremers, D. LSD-SLAM: Large-scale direct monocular SLAM. In Proceedings of the European Conference on Computer Vision; Springer: Berlin/Heidelberg, Germany, 2014; pp. 834–849. [Google Scholar]
- Forster, C.; Zhang, Z.; Gassner, M.; Werlberger, M.; Scaramuzza, D. SVO: Semidirect visual odometry for monocular and multicamera systems. IEEE Trans. Robot. 2016, 33, 249–265. [Google Scholar] [CrossRef] [Scilit]
- Gao, F.; Wu, W.; Lin, Y.; Shen, S. Online safe trajectory generation for quadrotors using fast marching method and bernstein basis polynomial. In Proceedings of the 2018 IEEE International Conference on Robotics and Automation (ICRA), Guangzhou, China, 17–19 November 2018; pp. 344–351. [Google Scholar]
- Gallego, G.; Delbrück, T.; Orchard, G.; Bartolozzi, C.; Taba, B.; Censi, A.; Leutenegger, S.; Davison, A.J.; Conradt, J.; Daniilidis, K.; et al. Event-based vision: A survey. IEEE Trans. Pattern Anal. Mach. Intell. 2020, 44, 154–180. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Butt, M.Z.; Nasir, N.; Rashid, R.B.A. A review of perception sensors, techniques, and hardware architectures for autonomous low-altitude UAVs in non-cooperative local obstacle avoidance. Robot. Auton. Syst. 2024, 173, 104629. [Google Scholar] [CrossRef] [Scilit]
- Steiner, J.A.; He, X.; Bourne, J.R.; Leang, K.K. Open-sector rapid-reactive collision avoidance: Application in aerial robot navigation through outdoor unstructured environments. Robot. Auton. Syst. 2019, 112, 211–220. [Google Scholar] [CrossRef] [Scilit]
- Holmberg, M.; Karlsson, O.; Tulldahl, M. LiDAR positioning for indoor precision navigation. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, New Orleans, LA, USA, 19–20 June 2022; pp. 359–368. [Google Scholar]
- Müller, H.; Niculescu, V.; Polonelli, T.; Magno, M.; Benini, L. Robust and efficient depth-based obstacle avoidance for autonomous miniaturized uavs. IEEE Trans. Robot. 2023, 39, 4935–4951. [Google Scholar] [CrossRef] [Scilit]
- Niculescu, V.; Müller, H.; Ostovar, I.; Polonelli, T.; Magno, M.; Benini, L. Towards a multi-pixel time-of-flight indoor navigation system for nano-drone applications. In Proceedings of the 2022 IEEE International Instrumentation and Measurement Technology Conference (I2MTC), Ottawa, ON, Canada, 16–19 May 2022; pp. 1–6. [Google Scholar]
- Giovinazzo, F.; Grella, F.; Sartore, M.; Adami, M.; Galletti, R.; Cannata, G. From CySkin to ProxySKIN: Design, implementation and testing of a multi-modal robotic skin for human–robot interaction. Sensors 2024, 24, 1334. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Tsuji, S.; Kohama, T. Proximity skin sensor using time-of-flight sensor for human collaborative robot. IEEE Sens. J. 2019, 19, 5859–5864. [Google Scholar] [CrossRef] [Scilit]
- Basnet, S.; Andersen, J.C.; Angelis, D.; Boukas, E. Towards an Alternative Low-Cost Perception System for Aerial Vehicles in Confined Spaces. In Proceedings of the 2025 IEEE International Conference on Imaging Systems and Techniques (IST), Strasbourg, France, 15–17 October 2025; pp. 1–6. [Google Scholar]
- Kayatas, E.; Celik, M. The effects of dihedral angle on hover rigidity and planar maneuvers in rotary-wing UAVs. Aircr. Eng. Aerosp. Technol. 2023, 95, 1029–1036. [Google Scholar] [CrossRef] [Scilit]
- Espinoza, A.A.; Pérez, J.; Fernández, Y.; Martínez, R. The effects of UAV quadcopter propeller tilt angle on flight stability. In Proceedings of the LACCEI International Multi-Conference Engineering, Education and Technology, Virtual, 27–31 July 2020; pp. 27–30. [Google Scholar]
- Kostavelis, I.; Boukas, E.; Nalpantidis, L.; Gasteratos, A. Visual odometry for autonomous robot navigation through efficient outlier rejection. In Proceedings of the 2013 IEEE International Conference on Imaging Systems and Techniques (IST), Beijing, China, 22–23 October 2013; pp. 45–50. [Google Scholar]
- Kostavelis, I.; Boukas, E.; Nalpantidis, L.; Gasteratos, A. Stereo-based visual odometry for autonomous robot navigation. Int. J. Adv. Robot. Syst. 2016, 13, 21. [Google Scholar] [CrossRef] [Scilit]
- STMicroelectronics. VL53L5CX—Multi-Zone Time-of-Flight (ToF) Ranging Sensor with Wide Field of View; STMicroelectronics: Geneva, Switzerland, 2024. [Google Scholar]
- Ulrich, I.; Borenstein, J. VFH+: Reliable obstacle avoidance for fast mobile robots. In Proceedings of the 1998 IEEE International Conference on Robotics and Automation (Cat. No. 98CH36146), Leuven, Belgium, 16–20 May 1998; Volume 2, pp. 1572–1577. [Google Scholar]
- Wang, X.; Cheng, M.; Zhang, S.; Gong, H. Multi-uav cooperative obstacle avoidance of 3d vector field histogram plus and dynamic window approach. Drones 2023, 7, 504. [Google Scholar] [CrossRef] [Scilit]
- Díaz, D.; Marín, L. VFH+ D: An improvement on the VFH+ algorithm for dynamic obstacle avoidance and local planning. IFAC-PapersOnLine 2020, 53, 9590–9595. [Google Scholar] [CrossRef] [Scilit]




| Property | Value |
|---|---|
| Size | 13 × 23 × 3 mm |
| Weight | 0.7 g (without header pins) |
| Operating voltage | 3.2–5.5 V |
| Max. range distance | 4000 mm |
| Min. range distance | 20 mm |
| Field of View (FoV) | 65° diagonal; 45° horizontal/vertical |
| SPI speed | Upto 3 MHz |
| Price per piece | 29.95 USD |
| Parameter | Teensy 4.1 | 12 × VL53L8CX | Hokuyo URG-04LX (2D LiDAR) | Ouster (3D LiDAR) |
|---|---|---|---|---|
| Operating voltage (V) | 4.9 | 3.2 | 5 | 12 |
| Operating current (A) | 0.07 | 0.88 | 0.5 | 1.5 |
| Power consumed (W) | 0.343 | 2.816 | 2.5 | 18 |
| Flight time (min) | 7.8 | 8.1 | 4 | |
| Weight (g) | 140 | 160 | 1100 | |
| Approx. Cost (USD) | 400 | 1000 | 5000 | |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Basnet, S.; Andersen, J.C.; Boukas, E. Design and Implementation of a Low-Cost Perception System for Aerial Robots in Confined Spaces. Sensors 2026, 26, 1140. https://doi.org/10.3390/s26041140
Basnet S, Andersen JC, Boukas E. Design and Implementation of a Low-Cost Perception System for Aerial Robots in Confined Spaces. Sensors. 2026; 26(4):1140. https://doi.org/10.3390/s26041140
Chicago/Turabian StyleBasnet, Susan, Jens Christian Andersen, and Evangelos Boukas. 2026. "Design and Implementation of a Low-Cost Perception System for Aerial Robots in Confined Spaces" Sensors 26, no. 4: 1140. https://doi.org/10.3390/s26041140
APA StyleBasnet, S., Andersen, J. C., & Boukas, E. (2026). Design and Implementation of a Low-Cost Perception System for Aerial Robots in Confined Spaces. Sensors, 26(4), 1140. https://doi.org/10.3390/s26041140